


1.0 INTRODUCTION
As automatic control systems can be very effective in reducing energy losses, they are widely used in industrial fields. However, such systems are susceptible to poor performance because the interaction between the human operator and the systems is often ignored. Also, unanticipated changes in the external environment can make the system defective. The effect of faults can be destructive if they are not detected early. So, practical fault detection and isolation (FDI) methods are essential. The primary task of FDI methods is to show that something is incorrect and specify which component has a fault. Progress in modelling methods has raised the possibility of applying model-based FDI methods. These have been considered a very efficient approach for FDI both in theory and in practice(Reference Chen and Patton1).
The control of uncertain systems exposed to an external perturbation has become an active field of study during the past decade. Most of the systems encountering problems of this kind in real terms are usually affected by various uncertainties such as parameter variations, actuator faults and non-linearities. In the majority of control strategies proposed in literature, it is assumed that all state variables are available. However, this is not always true in practice. Hence, a state vector needs to be estimated to be used in the control rules. The fault identification plan is mainly aimed at producing a warning when faults occur(Reference Khooban, Siahi and Soltanpour2). Among the common methods used to perform comparisons in this field are the Kalman filter(Reference Kalman3), adaptive observers(Reference Gevers and Bastin4), high-gain observers(Reference Hammouri and Othman5) and sliding mode observers (SMO)(Reference Utkin6-Reference Thein and Misawa9).
The SMO takes advantage of discontinuous control actions to move the observer error direction towards a certain hyper-plane in the fault space; from this point, the direction of the slide is maintained until the fault states converge to the origin. Basically, the observer generates the signals used to discover data associated with the fault. Remaining generation statements, used as linear observers, have been extensively applied. In this method, discrepancy between the system output and observer output is processed by a weighting matrix to form so called residuals. The remaining will equal zero if a fault does not occur in the process. However, it will reply specifically once a special fault occurs(Reference Frank10,Reference Magni and Mouyon11) .
In 1992, Utkin et al designed an ordinary observer with a discontinuous part that was fed back along with an appropriate gain(Reference Edwards and Spurgeon12). An observer where the output fault is fed back linearly was designed by Walcott and Zakin(Reference Walcott and Zak13), and a Lyapunov technique was applied to show its sustainability. A canonical form was proposed by Spurgeon and Edwards(Reference Edwards, Spurgeon and Patton14,Reference Edwards and Spurgeon15) for the design of an SMO that depends on the invariable zeros of the system and the particular conditions related to the input and output distribution matrices. They used both the linear and non-linear output error injection in that procedure. They also presented a procedure for calculating the linear output error injection gain. The solution is obvious. However, it does not make use of all the degrees of freedom. In Ref. Reference Tan and Edwards16, another canonical form was suggested by Edwards et al based on an adequate status in accordance with the linear matrix inequality (LMI). In that paper, the authors tried to utilise the freedom in the model proposed by Edwards(Reference Xiang, Su and Chu17) for sectional pole attribution. However, they did not determine the best position for eigenvalues in the region of interest.
In recent years, the sliding-mode method has been used widely to design controllers or state observers(Reference Lin, Xia, Shi and Wu18-Reference Wu, Shiand and Gao22). Sliding-mode method has been used in many studies(Reference Lin, Xia, Shi and Wu18,Reference Shi, Xia, Liu and Rees19) to control linear time invariant (LTI) and time variant systems (LTV) with uncertainties. In these studies, the superiority of the proposed methods is well-presented. But unfortunately, these methods cannot be used for non-linear systems due to the unstructured nature of uncertainties in them. Therefore, to have an effective control technique for linear systems, to overcome the uncertainties and to ensure the stability of the closed-loop system, control input coefficients must be increased. This, in turn, will lead to an increase in control input amplitude and consequently the saturation of actuators. In Refs Reference Chang, Wu, Lin, Chen and Chang20-Reference Wu, Shiand and Gao22, sliding-mode method was used as the controller or state observer in non-linear systems with uncertainty. Mathematical proof and simulation results have shown the acceptable performance of these methods. But in these studies, unlike the conventional methods, the integral of system states is used to determine the sliding surface. The use of an integral factor in a sliding surface will lead to an undesirable wind-up effect. So, the practical implementation of these methods will encounter problems(Reference Soltanpour, Zolfaghari, Soltani and Khooban23-Reference Soltanpour, Otadolajam and Khooban27).
It must be emphasised that ‘accurate’ fault reconstruction is very encouraging in non-linear systems, particularly in the presence of uncertainty. The notion of ‘accurate’ fault reconstruction has been considered by Edwards(Reference Edwards, Spurgeon and Patton14) for linear systems without uncertainty. When uncertainties are considered, all the sliding mode observer-based fault reconstruction results offer only an estimate of the fault signal. It is highly desirable to create a procedure for fault reconstruction in non-linear systems or to achieve conditions under which ‘accurate’ fault reconstruction is possible. Also, since FDI is needed for use in real engineering systems, the reconstruction fault signal needs to be based only on accessible measured data.
In this study, a simple SMO is proposed for a special of class of non-linear systems in the presence of faults/unknown inputs. All the parametric uncertainties/disturbances present in the system are modelled in the form of unknown inputs/faults. The unknown input can be a combination of immeasurable or unmeasured disturbances, unknown control actions, or un-modelled system dynamics. The novelty of this study lies in the choice of robust terms to deal with faults/unknown inputs. The methods of the researches use all the output information to deal with unknown inputs, and so require the reduced-order system itself to be stable in the sliding mode(Reference Edwards and Spurgeon15,Reference Jiang, Shi and Mao28-Reference Yan and Edwards30) . Moreover, the robust terms are applied to ‘reconstruct’ all the faults/unknown inputs from the sliding mode. Finally, an HIRM aircraft system example is given to illustrate the efficiency of the proposed approach.
The organisation of this paper is as follows:
In Section 2, the dynamic equations of a non-linear system and necessary assumptions for the design of an SMO are introduced. In Section 3, the design details of the SMO are described. Section 4 discusses the selection of the sliding surface and the necessary conditions for existence of the sliding surface. In Section 5, using mathematical analysis, we try to obtain the conditions for making the error zero. In Section 6, fault reconstruction using the sliding mode is explained. In Section 7, the advantages of the proposed method are explained. In Section 8, the dynamic equations of the HIRM aircraft system are introduced. The simulation results of the proposed observer are presented and discussed in Section 9. Finally, conclusions are drawn in Section 10.
2.0 FORMULATING THE PROBLEM
Consider the following system(Reference Veluvolu and Soh31):
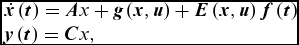 $$\begin{equation}
\begin{array}{l}
\skew4\dot{\boldsymbol{x}}( \boldsymbol{t} ) = \boldsymbol{Ax} + \boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) + \boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} )\\
\boldsymbol{y}( \boldsymbol{t} ) = \boldsymbol{Cx},
\end{array}
\end{equation}$$
where x ∈ Rn is the state vector; u ∈ Rq is the input vector and y ∈ Rp is the output vector; f (t) ∈ Rm shows the actuator fault; A,C and E are known constant real matrices of suitable dimensions; the pair (A,C) are observable; g(x, u) is a continuous non-linear vector function, assumed to be Lipschitz, with a Lipschitz constant lg, i.e. ||g( $\hat x$,u)− g(x,u)|| ≤ lg ||
 $\hat x - x$||. It is assumed that the derivative of f (t) with respect to time is norm-bounded, i.e.
 $\| {\dot f(t)} \| \le {f_1}$, where f 1 ≥ 0.
Assumption 1: Matrix C is a full rank matrix and the pair (A, C) is observable.
Thanks to C being a full rank matrix, we consider that the first m rows (outputs) of matrix C form a full rank m×n matrix C1 such that
 $$\begin{equation*}
{\boldsymbol{C}_1} = \boldsymbol{\ }{[ {\begin{array}{*{20}{c}} {{\boldsymbol{C}_{11}}}&{{\boldsymbol{C}_{12}}} \end{array}} ]_{\boldsymbol{m} \times \boldsymbol{n}}};{\boldsymbol{ Rank}}}{\left[ {{\boldsymbol{C}_{11}}} \right]_{\boldsymbol{m} \times \boldsymbol{m}}} = \boldsymbol{m}.
\end{equation*}$$
Thus, Rank (C1) = m. By partitioning the output distribution matrix, the following equations could be obtained:
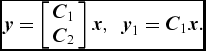 $$\begin{equation*}
\boldsymbol{y} = \left[ {\begin{array}{*{20}{c}} {{\boldsymbol{C}_1}}\\ {{\boldsymbol{C}_2}} \end{array}} \right]\boldsymbol{x},\boldsymbol{\ }\;{\boldsymbol{y}_1} = {\boldsymbol{C}_1}\boldsymbol{x}.
\end{equation*}$$
The following result depends on the observability of faults/unknown inputs from measurements of the output. The following assumptions on the fault distribution matrix are the basic needs for the expansion of the SMO that can use the faults in the sliding mode.
Assumption 2: The function E(x, u) and the inverse of the non-linear matrix C1E(x, u), exist and are bounded ∀x ∈ M and u ∈ U.
Assumption 3: The non-linear functions g(x, u) and E(x, u) fulfil the Lipschitz conditions so that
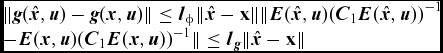 $$\begin{equation*}
\begin{array}{l}
\| {\boldsymbol{g}}( \skew3\hat{\boldsymbol{x}},\boldsymbol{u} ) - \boldsymbol{g}({\boldsymbol{x},\boldsymbol{u}} ) \| \le {\boldsymbol{l}_\phi }\| {\skew3\hat{\boldsymbol{x}} - {{\bf x}}} \| \| {\boldsymbol{E}}(\skew3\hat{\boldsymbol{x}},\boldsymbol{u} ){{(\boldsymbol{C}_1\boldsymbol{E}(\skew3\hat{\boldsymbol{x}},\boldsymbol{u} ))}^{ - 1}}\\
- \boldsymbol{E}(\boldsymbol{x},\boldsymbol{u} ){{({\boldsymbol{C}_1}\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} ))}^{ - 1}} \| \le {\boldsymbol{l}_\boldsymbol{g}}\| \skew3\hat{\boldsymbol{x}} - {{\bf x}} \| \end{array}
\end{equation*}$$
for some Lipschitz constants  ${\boldsymbol{l}_\phi }$ and
 ${\boldsymbol{l}_\boldsymbol{g}}$.
Remark 1: In this paper, all parametric uncertainties/disturbances affecting the system are modelled as unknown inputs/faults. In order to generalise the expansion, the fault distribution matrix E(x, u) is intended to be non-linear without any constraint.
3.0 THE DESIGN OF THE SLIDING MODE OBSERVER
For Equation (1), an observer, as follows, can be developed to estimate the states:
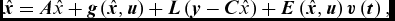 $$\begin{equation}
{\skew3\hat{\boldsymbol{x}}} = \boldsymbol{A\hat{x}} + \boldsymbol{g}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ) + \boldsymbol{L}( {\boldsymbol{y} - \boldsymbol{C\hat{x}}} ) + \boldsymbol{E}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} )\boldsymbol{v}( \boldsymbol{t} ),
\end{equation}$$
where L is the feedback gain and v(t) is the robust term provided by the sliding-mode estimation(Reference Veluvolu and Soh31):
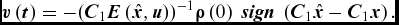 $$\begin{equation}
\boldsymbol{v}( \boldsymbol{t} ) = - {({\boldsymbol{C}_1}\boldsymbol{E}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ))^{ - 1}}\boldsymbol{\rho }( 0 )\;{\boldsymbol{sign}}\;( {{\boldsymbol{C}_1}\skew3\hat{\boldsymbol{x}} - {\boldsymbol{C}_1}\boldsymbol{x}} ).
\end{equation}$$
Also, ρ(.) is a positive scalar function that needs to be specified.
Remark 2: In the above observer development, the disturbance inputs are substituted by robust terms. The number of robust terms v(t) is equivalent to the number of fault inputs fi(t).
By defining the estimation error as e =  $\skew3\hat{\boldsymbol{x}}$ − x, the estimation error dynamics can be calculated from Equations (1) and (2) as
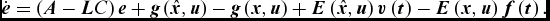 $$\begin{equation}
\dot{\boldsymbol{e}} = ( {\boldsymbol{A} - \boldsymbol{LC}} )\boldsymbol{e} + \boldsymbol{g}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ) - \boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) + \boldsymbol{E}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} )\boldsymbol{v}( \boldsymbol{t} ) - \boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ).
\end{equation}$$
Because the non-linear matrix E(.) and faults f(t) are limited, the boundedness of the error dynamics can be ensured with an appropriate selection of feedback gain L using the standard Lyapunov analysis.
4.0 DESIGN OF SLIDING MODE SURFACE FOR FAULTDETECTION
The selection of sliding-mode gain ρ(.) to guarantee the existence of the sliding mode will be reviewed in this section. The main purpose of the robust terms v(t) in Equation (2) is to compensate for fault inputs and improve the integrity of estimation. This approach can be expressed as follows:
1. Describe the following sliding surfaces(Reference Veluvolu and Soh31):
(5) $$\begin{equation}
{e_{y1}} = {\boldsymbol{C}_1}e = 0;\;{\rm{that}}\,{\rm{is}},\;{e_{yi}} = 0,\;{\rm{for}}\;{\rm{all}}\;i = 1,2, \ldots ,m.\end{equation}$$
2. Design the sliding-mode estimation as Equation (2) with v(t) presented by Equation (3) so that the system can achieve the sliding mode.
3. Make sure that the reduced-order estimation error dynamics goes toward zero on the sliding surfaces of e y1 = 0, e y2 = 0, …, e ym = 0.
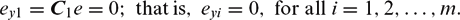
By defining ey = C1e, we have
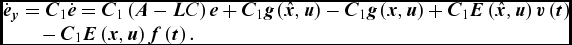 $$\begin{equation}
\begin{array}{l}
{\dot{\boldsymbol{e}}_\boldsymbol{y}} = {\boldsymbol{C}_1}\dot{\boldsymbol{e}} = {\boldsymbol{C}_1}( {\boldsymbol{A} - \boldsymbol{LC}} )\boldsymbol{e} + {\boldsymbol{C}_1}\boldsymbol{g}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{C}_1}\boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) + {\boldsymbol{C}_1}\boldsymbol{E}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} )\boldsymbol{v}( \boldsymbol{t} )\\
\qquad -\, {\boldsymbol{C}_1}\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ).\end{array}
\end{equation}$$
By inserting Equation (4) into Equation (6), we have
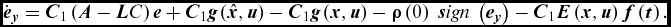 $$\begin{equation}
{\dot{\boldsymbol{e}}_\boldsymbol{y}} = {\boldsymbol{C}_1}( {\boldsymbol{A} - \boldsymbol{LC}} )\boldsymbol{e} + {\boldsymbol{C}_1}\boldsymbol{g}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{C}_1}\boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) - \boldsymbol{\rho }( 0 )\;\boldsymbol{sign}\;( {{\boldsymbol{e}_\boldsymbol{y}}} ) - {\boldsymbol{C}_1}\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ).
\end{equation}$$
The stability of the reduced-order dynamics can be easily analysed in the transformed domain. From Assumptions 1 and 2, we have det(C11) ≠ 0; then, there exists a non-singular transformation
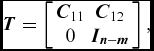 $$\begin{equation}
\boldsymbol{T} = \left[ {\begin{array}{*{20}{c}} {{\boldsymbol{C}_{11}}}&{{\boldsymbol{C}_{12}}}\\ 0&{{\boldsymbol{I}_{\boldsymbol{n} - \boldsymbol{m}}}} \end{array}} \right],
\end{equation}$$
with the following transformed matrices:
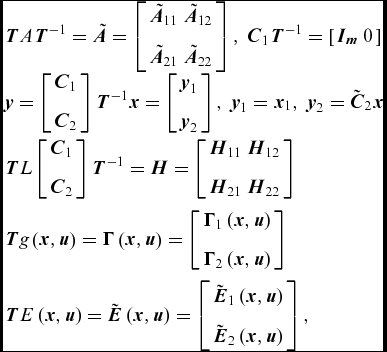 $$\begin{equation}
\begin{array}{l} \boldsymbol{TA}{\boldsymbol{T}^{ - 1}} = \skew6\tilde{\boldsymbol{A}} = \left[ {\begin{array}{*{20}{c}} {{{\skew6\tilde{\boldsymbol{A}}}_{11}}}&{{{\skew6\tilde{\boldsymbol{A}}}_{12}}}\\
{{{\skew6\tilde{\boldsymbol{A}}}_{21}}}&{{{\skew6\tilde{\boldsymbol{A}}}_{22}}} \end{array}} \right],\boldsymbol{\ }{\boldsymbol{C}_1}{\boldsymbol{T}^{ - 1}} = [ {\begin{array}{*{20}{c}} {{\boldsymbol{I}_\boldsymbol{m}}}&0 \end{array}} ]\\
\boldsymbol{y} = \left[ {\begin{array}{*{20}{c}} {{\boldsymbol{C}_1}}\\ {{\boldsymbol{C}_2}} \end{array}} \right]{\boldsymbol{T}^{ - 1}}\boldsymbol{x} = \left[ {\begin{array}{*{20}{c}} {{\boldsymbol{y}_1}}\\ {{\boldsymbol{y}_2}} \end{array}} \right],\boldsymbol{\ }{\boldsymbol{y}_1} = {\boldsymbol{x}_1},\boldsymbol{\ }{\boldsymbol{y}_2} = {{\tilde{\boldsymbol{C}}}_2}\boldsymbol{x}\\[12pt] \boldsymbol{TL}\left[ {\begin{array}{*{20}{c}} {{\boldsymbol{C}_1}}\\ {{\boldsymbol{C}_2}} \end{array}} \right]{\boldsymbol{T}^{ - 1}} = \boldsymbol{H} = \left[ {\begin{array}{*{20}{c}} {{\boldsymbol{H}_{11}}}&{{\boldsymbol{H}_{12}}}\\ {{\boldsymbol{H}_{21}}}&{{\boldsymbol{H}_{22}}} \end{array}} \right]\\[15pt] \boldsymbol{Tg}( {\boldsymbol{x},\boldsymbol{u}} ) = {{\bf \Gamma }}( {\boldsymbol{x},\boldsymbol{u}} ) = \left[ {\begin{array}{*{20}{c}} {{{{\bf \Gamma }}_1}( {\boldsymbol{x},\boldsymbol{u}} )}\\ {{{{\bf \Gamma }}_2}( {\boldsymbol{x},\boldsymbol{u}} )} \end{array}} \right]\\[15pt] \boldsymbol{TE}( {\boldsymbol{x},\boldsymbol{u}} ) = \tilde{\boldsymbol{E}}( {\boldsymbol{x},\boldsymbol{u}} ) = \left[ {\begin{array}{*{20}{c}} {{{\tilde{\boldsymbol{E}}}_1}( {\boldsymbol{x},\boldsymbol{u}} )}\\ {{{\tilde{\boldsymbol{E}}}_2}( {\boldsymbol{x},\boldsymbol{u}} )} \end{array}} \right], \end{array}
\end{equation}$$
where x 1 is measurable output.
Now, we have 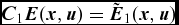 ${\boldsymbol{C}_1}\boldsymbol{E}(\boldsymbol{x},\boldsymbol{u}) = {\tilde{\boldsymbol{E}}_1}( {\boldsymbol{x},\boldsymbol{u}} )$. By defining
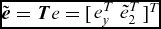 $\tilde{\boldsymbol{e}} = \boldsymbol{T}e = {[{e_{y}^T} \,\, {\tilde{e_{2}}^T}}]^{T}}$, we transform the error dynamics of Equation (7) with the transformation in Equation (8) to the form
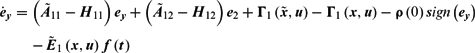 $$\begin{eqnarray}
{\dot{\boldsymbol{e}}_\boldsymbol{y}} &=& ( {{{\skew6\tilde{\boldsymbol{A}}}_{11}} - {\boldsymbol{H}_{11}}} ){\boldsymbol{e}_\boldsymbol{y}} + ( {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} ){\boldsymbol{e}_2} + {{\boldsymbol{\Gamma }}_1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {{{\bf \Gamma }}_1}( {\boldsymbol{x},\boldsymbol{u}} ) - \boldsymbol{\rho }( 0 )\boldsymbol{sign}( {{\boldsymbol{e}_\boldsymbol{y}}} )\nonumber\\
&& -\, {\tilde{\boldsymbol{E}}_1}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} )
\end{eqnarray}$$
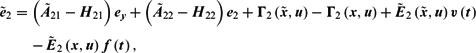 $$\begin{eqnarray}
{{\tilde{\boldsymbol{e}}}_2} &=& ( {{{\skew6\tilde{\boldsymbol{A}}}_{21}} - {\boldsymbol{H}_{21}}} ){\boldsymbol{e}_\boldsymbol{y}} + ( {{{\skew6\tilde{\boldsymbol{A}}}_{22}} - {\boldsymbol{H}_{22}}} ){\boldsymbol{e}_2} + {{{\bf \Gamma }}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {{{\bf \Gamma }}_2}( {\boldsymbol{x},\boldsymbol{u}} ) + {\tilde{\boldsymbol{E}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )\boldsymbol{v}( \boldsymbol{t} )\nonumber\\
&& -\, {\tilde{\boldsymbol{E}}_2}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ),
\end{eqnarray}$$
where H is the feedback gain matrix in the transformed domain. According to the transformation, all the states in the subsystem e y are measurable. Considering the generality of the problem, H11 can be chosen to be of full rank.
Lemma 1: For the systems of Equations (10) and (11) fulfilling Assumptions 1-3 are driven to the sliding surface of Equation (5) in limited time and stay on it if the sliding-mode gain ρ(.) in Equation (7) fulfils
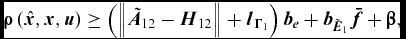 $$\begin{equation}
\boldsymbol{\rho }( {\skew3\hat{\boldsymbol{x}},\boldsymbol{x},\boldsymbol{u}} ) \ge ( {\left\| {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} \right\| + {\boldsymbol{l}_{{{{\bf \Gamma }}_1}}}} ){\boldsymbol{b}_\boldsymbol{e}} + {\boldsymbol{b}_{{{\tilde{\boldsymbol{E}}}_1}}}\skew5\bar\boldsymbol{f} + \boldsymbol{\beta },
\end{equation}$$
where ||e|| ≤ be and β is a positive constant.
Proof: Consider the Lyapunov function 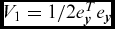 ${V_1} = {1}/{2}e_\boldsymbol{y}^T{e_\boldsymbol{y}}$, differentiating with respect to time and using Equation (11), we have(Reference Veluvolu and Soh31)
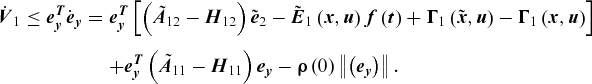 $$\begin{eqnarray}
{\dot{\boldsymbol{V}}_1} \le \boldsymbol{e}_\boldsymbol{y}^\boldsymbol{T}{\dot{\boldsymbol{e}}_\boldsymbol{y}} &=& \boldsymbol{e}_\boldsymbol{y}^\boldsymbol{T}\left[ {( {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} ){{\tilde{\boldsymbol{e}}}_2} - {{\tilde{\boldsymbol{E}}}_1}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ) + {{{\bf \Gamma }}_1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {{{\bf \Gamma }}_1}( {\boldsymbol{x},\boldsymbol{u}} )} \right] \\
&&+ \boldsymbol{e}_\boldsymbol{y}^\boldsymbol{T}( {{{\skew6\tilde{\boldsymbol{A}}}_{11}} - {\boldsymbol{H}_{11}}} ){\boldsymbol{e}_\boldsymbol{y}} - \boldsymbol{\rho }( 0 )\left\| {( {{\boldsymbol{e}_\boldsymbol{y}}} )} \right\|.
\end{eqnarray}$$
From Assumption 2, we have 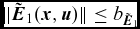 $\| {{{\tilde{\boldsymbol{E}}}_1}(\boldsymbol{x},\boldsymbol{u})} \| \le {b_{{{\tilde{\boldsymbol{E}}}_1}}}$ for some upper bound
 ${b_{{{\tilde{\boldsymbol{E}}}_1}}}$. From the Lipschitz condition in Assumption 3, we have
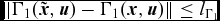 $\| {{\Gamma _1}(\tilde{\boldsymbol{x}},\boldsymbol{u}) - {\Gamma _1}(\boldsymbol{x},\boldsymbol{u})} \| \le {{{l}}_{{\Gamma _1}}}$ for some Lipschitz constant l Γ1.
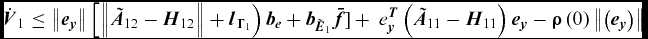 $$\begin{equation}
{\dot{\boldsymbol{V}}_1} \le \left\| {{\boldsymbol{e}_\boldsymbol{y}}} \right\|\left[ {\left\| {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} \right\| + {\boldsymbol{l}_{{{{\bf \Gamma }}_1}}}} ){\boldsymbol{b}_\boldsymbol{e}} + {\boldsymbol{b}_{{{\tilde{\boldsymbol{E}}}_1}}}\skew5\bar\boldsymbol{f}] + \boldsymbol{\ e}_\boldsymbol{y}^\boldsymbol{T}( {{{\skew6\tilde{\boldsymbol{A}}}_{11}} - {\boldsymbol{H}_{11}}} ){\boldsymbol{e}_\boldsymbol{y}} - \boldsymbol{\rho }( 0 )\left\| {( {{\boldsymbol{e}_\boldsymbol{y}}} )} \right\|
\end{equation}$$
From Equation (14) we conclude that
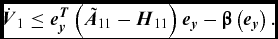 $$\begin{equation*}
{\dot{\boldsymbol{V}}_1} \le \boldsymbol{e}_\boldsymbol{y}^\boldsymbol{T}( {{{\skew6\tilde{\boldsymbol{A}}}_{11}} - {\boldsymbol{H}_{11}}} ){\boldsymbol{e}_\boldsymbol{y}} - \boldsymbol{\beta }( {{\boldsymbol{e}_\boldsymbol{y}}} ).
\end{equation*}$$
Because H11 is of full rank, we can choose H11 such that 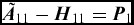 ${\skew6\tilde{\boldsymbol{A}}_{11}} - {\boldsymbol{H}_{11}} = {\boldsymbol{P}_1}$, where P1 > 0 is positive definite. So,
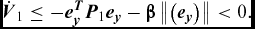 $$\begin{equation*}
{\dot{\boldsymbol{V}}_1} \le - \boldsymbol{e}_\boldsymbol{y}^\boldsymbol{T}{\boldsymbol{P}_1}{\boldsymbol{e}_\boldsymbol{y}} - \boldsymbol{\beta }\left\| {( {{\boldsymbol{e}_\boldsymbol{y}}} )} \right\| < 0.
\end{equation*}$$
Thus, the gain in Equation (14) guarantees that the sliding surface can be achieved in a limited time.
5.0 CHECK THE ERROR CONVERGENCE IN THE PROPOSED METHOD
By substituting the tantamount output error infusion signal into the error dynamics Equation (8), the error dynamics in the sliding mode could be obtained(Reference Veluvolu and Soh31). In the sliding mode e y = 0, we have  ${\dot e_y} = 0$. So, the tantamount output error infusion signal of v(t), veq can be obtained from Equation (10) according to(Reference Utkin6) as follows:
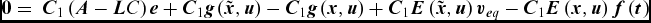 $$\begin{equation}
{{\bf 0}} = \boldsymbol{\ }{\boldsymbol{C}_1}( {\boldsymbol{A} - \boldsymbol{LC}} )\boldsymbol{e} + {\boldsymbol{C}_1}\boldsymbol{g}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{C}_1}\boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) + {\boldsymbol{C}_1}\boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){\boldsymbol{v}_{\boldsymbol{eq}}} - {\boldsymbol{C}_1}\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} )
\end{equation}$$
So,
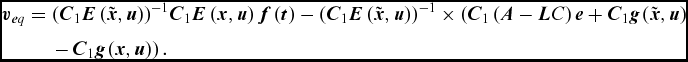 $$\begin{eqnarray}
{\boldsymbol{v}_{\boldsymbol{eq}}} &=& {( {{\boldsymbol{C}_1}\boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )} )^{ - 1}}{\boldsymbol{C}_1}\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ) - {( {{\boldsymbol{C}_1}\boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )} )^{ - 1}} \times ( {\boldsymbol{C}_1}( {\boldsymbol{A} - \boldsymbol{LC}} )\boldsymbol{e} + {\boldsymbol{C}_1}\boldsymbol{g}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )\right.\\
&&\left. -\, {\boldsymbol{C}_1}\boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) ).
\end{eqnarray}$$
By replacing the tantamount output error infusion signal into the error dynamics Equation (8), we have the following estimation of error dynamics in the sliding mode of ey = 0.
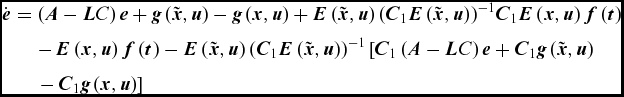 $$\begin{eqnarray}
\dot{\boldsymbol{e}} = ( {\boldsymbol{A} - \boldsymbol{LC}} )\boldsymbol{e} + \boldsymbol{g}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - \boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) + \boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){( {{\boldsymbol{C}_1}\boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )} )^{ - 1}}{\boldsymbol{C}_1}\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} )\\
&& - \,\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ) - \boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){( {{\boldsymbol{C}_1}\boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )} )^{ - 1}}\left[ {\boldsymbol{C}_1}( {\boldsymbol{A} - \boldsymbol{LC}} )\boldsymbol{e} + {\boldsymbol{C}_1}\boldsymbol{g}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )\right.\\
&&\left. -\, {\boldsymbol{C}_1}\boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) \right]
\end{eqnarray}$$
From the above error dynamics, it is obvious that the fault dynamics 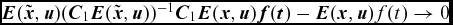 $\boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){( {{\boldsymbol{C}_1}\boldsymbol{E}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )} )^{ - 1}}{\boldsymbol{C}_1}\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ) - \boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} ){{f}}( {{t}} ) \to 0$ as
 $\tilde{\boldsymbol{x}} \to \boldsymbol{x}$. Through an appropriate design of the feedback gain, the error dynamics can be stabilised. For convenience of analysis, feedback gain design that stabilises the error dynamics will be reviewed in the transformed domain. By assessment of the tantamount output error infusion signal from Equation (16) and replacing it in Equation (11), we have
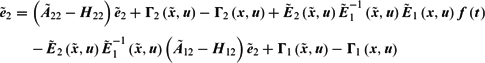 $$\begin{eqnarray}
{{\tilde{\boldsymbol{e}}}_2} &=& ( {{{\skew6\tilde{\boldsymbol{A}}}_{22}} - {\boldsymbol{H}_{22}}} ){{\tilde{\boldsymbol{e}}}_2} + {\boldsymbol{\Gamma }_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_2}( {\boldsymbol{x},\boldsymbol{u}} ) + {{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ) \\
&&-\, {{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )( {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} ){{\tilde{\boldsymbol{e}}}_2} + {\boldsymbol{\Gamma }_1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_1}( {\boldsymbol{x},\boldsymbol{u}} )
\end{eqnarray}$$
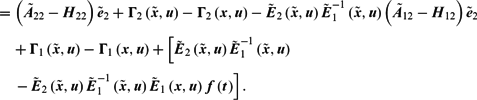 $$\begin{eqnarray}
&=& ( {{{\skew6\tilde{\boldsymbol{A}}}_{22}} - {\boldsymbol{H}_{22}}} ){{\tilde{\boldsymbol{e}}}_2} + {\boldsymbol{\Gamma }_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_2}( {\boldsymbol{x},\boldsymbol{u}} ) - {{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )( {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} ){{\tilde{\boldsymbol{e}}}_2} \\
&&+\, {\boldsymbol{\Gamma }_1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_1}( {\boldsymbol{x},\boldsymbol{u}} ) + \left[ {{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )\right.\\
&&\left. -\, {{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ) \right].\end{equation}$$
The following Lemma 1 discusses the stability of reduced-order estimation error Equation (19) in the sliding mode.
Theorem 1: For the system (1) fulfilling Assumptions 1-3 and using the estimator (2), the sliding-mode gain (12) guarantees that the estimation error is asymptotically stable in the multiple sliding mode of e y1=0, … , eym offered the gain H22 fulfils(Reference Veluvolu and Soh31)
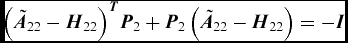 $$\begin{equation}
{( {{{\skew6\tilde{\boldsymbol{A}}}_{22}} - {\boldsymbol{H}_{22}}} )^\boldsymbol{T}}{\boldsymbol{P}_2} + {\boldsymbol{P}_2}( {{{\skew6\tilde{\boldsymbol{A}}}_{22}} - {\boldsymbol{H}_{22}}} ) = - \boldsymbol{I}
\end{equation}$$
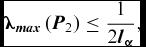 $$\begin{equation}
{\boldsymbol{\lambda }_{{\boldsymbol{max}}}}( {{\boldsymbol{P}_2}} ) \le \frac{1}{{2{\boldsymbol{l}_\boldsymbol{\alpha }}}},
\end{equation}$$
where 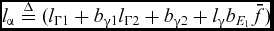 ${l_\alpha } \buildrel \Delta \over = ( {{l_{\Gamma 1}} + {b_{\gamma 1}}{l_{\Gamma 2}} + {b_{\gamma 2}} + {l_\gamma }{b_{{E_1}}}\bar f} )$ for some Lipschitz constants l Γ1, l Γ2, l γ and some upper bounds
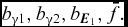 ${b_{\gamma 1}},{b_{\gamma 2}},{b_{{\boldsymbol{E}_1}}},\bar f.$
Proof: In the sliding mode, we have ey = 0, so  $\boldsymbol{e} \equiv {[0{{e}}_2^{{T}}]^{{T}}}$. Under the same Lipschitz conditions as in Assumption 3, we have
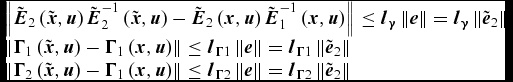 $$\begin{equation}
\begin{array}{l} \left\| {{{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_2}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {{\tilde{\boldsymbol{E}}}_2}( {\boldsymbol{x},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\boldsymbol{x},\boldsymbol{u}} )} \right\| \le {\boldsymbol{l}_\boldsymbol{\gamma }}\left\| \boldsymbol{e} \right\| = {\boldsymbol{l}_\boldsymbol{\gamma }}\left\| {{{\tilde{\boldsymbol{e}}}_2}} \right\|\\ \left\| {{\boldsymbol{\Gamma }_1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_1}( {\boldsymbol{x},\boldsymbol{u}} )} \right\| \le {\boldsymbol{l}_{\boldsymbol{\Gamma }1}}\left\| \boldsymbol{e} \right\| = {\boldsymbol{l}_{\boldsymbol{\Gamma }1}}\left\| {{{\tilde{\boldsymbol{e}}}_2}} \right\|\\ \left\| {{\boldsymbol{\Gamma }_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_1}( {\boldsymbol{x},\boldsymbol{u}} )} \right\| \le {\boldsymbol{l}_{\boldsymbol{\Gamma }2}}\left\| \boldsymbol{e} \right\| = {\boldsymbol{l}_{\boldsymbol{\Gamma }2}}\left\| {{{\tilde{\boldsymbol{e}}}_2}} \right\| \end{array}
\end{equation}$$
for some Lipschitz constants l Γ1 and l Γ2. Because the known functions are bounded based on Assumption 2, we have
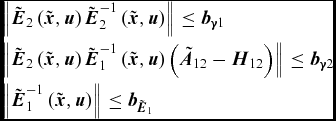 $$\begin{equation}
\begin{array}{l} \left\| {{{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_2}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )} \right\| \le {\boldsymbol{b}_{\boldsymbol{\gamma }1}}\\[6pt] \left\| {{{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )( {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} )} \right\| \le {\boldsymbol{b}_{\boldsymbol{\gamma }2}}\\[6pt] \left\| {{{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )} \right\| \le {\boldsymbol{b}_{{{\tilde{\boldsymbol{E}}}_1}}} \end{array}
\end{equation}$$
for some upper bounds b γ1, b γ2 and  ${b_{{{\tilde{\boldsymbol{E}}}_1}}}$. Now, we select the Lyapunov function candidate as
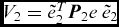 ${V_2} = \tilde e_2^{{T}}{\boldsymbol{P}_2}e\ {\tilde e_2}$. Differentiating according to time, and by using Equation (19), we have
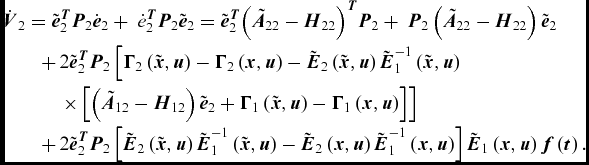 $$\begin{equation}
\begin{array}{l}
{{\dot{\boldsymbol{V}}}_2} = \tilde{\boldsymbol{e}}_2^\boldsymbol{T}{\boldsymbol{P}_2}{{\dot{\boldsymbol{e}}}_2} + \boldsymbol{\ \dot e}_2^\boldsymbol{T}{\boldsymbol{P}_2}{{\tilde{\boldsymbol{e}}}_2} = \tilde{\boldsymbol{e}}_2^\boldsymbol{T}{( {{{\skew6\tilde{\boldsymbol{A}}}_{22}} - {\boldsymbol{H}_{22}}} )^\boldsymbol{T}}{\boldsymbol{P}_2} + \boldsymbol{\ }{\boldsymbol{P}_2}( {{{\skew6\tilde{\boldsymbol{A}}}_{22}} - {\boldsymbol{H}_{22}}} ){{\tilde{\boldsymbol{e}}}_2} \\[6pt]
\qquad+\, 2\tilde{\boldsymbol{e}}_2^\boldsymbol{T}{\boldsymbol{P}_2}\left[ {\boldsymbol{\Gamma }_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_2}( {\boldsymbol{x},\boldsymbol{u}} ) - {{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} )\right.\\[6pt]
\quad\qquad\left. \times \left[ {( {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} ){{\tilde{\boldsymbol{e}}}_2} + {\boldsymbol{\Gamma }_1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_1}( {\boldsymbol{x},\boldsymbol{u}} )} \right] \right]\\[6pt]
\qquad +\, 2\tilde{\boldsymbol{e}}_2^\boldsymbol{T}{\boldsymbol{P}_2}\left[ {{{\tilde{\boldsymbol{E}}}_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {{\tilde{\boldsymbol{E}}}_2}( {\boldsymbol{x},\boldsymbol{u}} ){{\tilde{\boldsymbol{E}}}_1}^{ - 1}( {\boldsymbol{x},\boldsymbol{u}} )} \right]{{\tilde{\boldsymbol{E}}}_1}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ).
\end{array}
\end{equation}$$
Considering the above results, we have
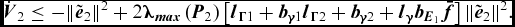 $$\begin{equation*}
{\dot{\boldsymbol{V}}_2} \le - {\left\| {{{\tilde{\boldsymbol{e}}}_2}} \right\|^2} + 2{\boldsymbol{\lambda }_{{\boldsymbol{max}}}}( {{\boldsymbol{P}_2}} )\left[ {{\boldsymbol{l}_{\boldsymbol{\Gamma }1}} + {\boldsymbol{b}_{\boldsymbol{\gamma }1}}{\boldsymbol{l}_{\boldsymbol{\Gamma }2}} + {\boldsymbol{b}_{\boldsymbol{\gamma }2}} + {\boldsymbol{l}_\boldsymbol{\gamma }}{\boldsymbol{b}_{{\boldsymbol{E}_1}}}\skew5\bar\boldsymbol{f}} \right]{\left\| {{{\tilde{\boldsymbol{e}}}_2}} \right\|^2}.
\end{equation*}$$
If the estimation gain H is designed so that conditions in Equations (20) and (21) are fulfilled, the error dynamics in the sliding mode will be asymptotically stable.
Remark 3: If the fault distribution matrix  $\tilde{\boldsymbol{E}}$ is a constant matrix or only involves functions of y1 outputs, that is,
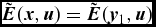 $\tilde{\boldsymbol{E}}(\boldsymbol{x},\boldsymbol{u}) = \tilde{\boldsymbol{E}}({\boldsymbol{y}_1},\boldsymbol{u})$, then the reduced-order error dynamics will be completely free from faults. In the sliding mode, e y = 0; therefore,
 $\tilde{\boldsymbol{E}}({\boldsymbol{x}^ \wedge },\boldsymbol{u})$;
 $\tilde{\boldsymbol{E}}({\boldsymbol{y}_1},\boldsymbol{u})$. Hence, we have
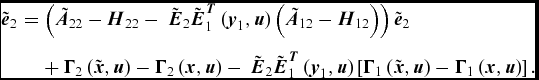 $$\begin{eqnarray*}
{{\tilde{\boldsymbol{e}}} _2} &=& ( {{{\skew6\tilde{\boldsymbol{A}}}_{22}} - {\boldsymbol{H}_{22}} - \boldsymbol{\ }{{\tilde{\boldsymbol{E}}}_2}{{\tilde{\boldsymbol{E}}}_1}^\boldsymbol{T}( {{\boldsymbol{y}_1},\boldsymbol{u}} )( {{{\skew6\tilde{\boldsymbol{A}}}_{12}} - {\boldsymbol{H}_{12}}} )} ){\tilde{\boldsymbol{e}}_2}\\
&& +\, {\boldsymbol{\Gamma }_2}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_2}( {\boldsymbol{x},\boldsymbol{u}} ) - \boldsymbol{\ }{\tilde{\boldsymbol{E}}_2}{\tilde{\boldsymbol{E}}_1}^\boldsymbol{T}( {{\boldsymbol{y}_1},\boldsymbol{u}} )\left[ {{\boldsymbol{\Gamma }_1}( {\tilde{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{\Gamma }_1}( {\boldsymbol{x},\boldsymbol{u}} )} \right].
\end{eqnarray*}$$
The gain design now depends on the matrix 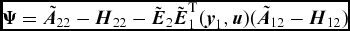 $\boldsymbol{\Psi } = {\skew6\tilde{\boldsymbol{A}}_{22}} - {\boldsymbol{H}_{22}} - {\tilde{\boldsymbol{E}}_2}{\tilde{\boldsymbol{E}}_1}^{\rm{T}}({\boldsymbol{y}_1},\boldsymbol{u})({\skew6\tilde{\boldsymbol{A}}_{12}} - {\boldsymbol{H}_{12}})$. The conditions that will guarantee stability are reduced to the form
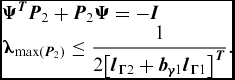 $$\begin{equation*}
\begin{array}{l} {\boldsymbol{\Psi }^\boldsymbol{T}}{\boldsymbol{P}_2} + {\boldsymbol{P}_2}\boldsymbol{\Psi } = - \boldsymbol{I}\\ {\boldsymbol{\lambda }_{\max ( {{\boldsymbol{P}_2}} )}} \le \displaystyle\frac{1}{{2{{\left[ {{\boldsymbol{l}_{\boldsymbol{\Gamma }2}} + {\boldsymbol{b}_{\boldsymbol{\gamma }1}}{\boldsymbol{l}_{\boldsymbol{\Gamma }1}}} \right]}^\boldsymbol{T}}}}. \end{array}
\end{equation*}$$
6.0 FAULT RECOVERY FROM THE SLIDING MODE OBSERVER
The equivalent output error injection signal veq in Equation (16) is needed for the existence of the sliding mode(Reference Utkin6,Reference Edwards, Spurgeon and Patton14) and is rewritten as(Reference Veluvolu and Soh31):
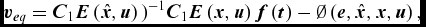 $$\begin{equation}
{\boldsymbol{v}_{\boldsymbol{eq}}} = {\boldsymbol{C}_1}\boldsymbol{E}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ){)^{ - 1}}{\boldsymbol{C}_1}\boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} ) - \emptyset ( {\boldsymbol{e},\skew3\hat{\boldsymbol{x}},\boldsymbol{x},\boldsymbol{u}} ),
\end{equation}$$
where
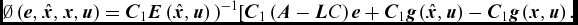 $$\begin{equation}
\emptyset ( {\boldsymbol{e},\skew3\hat{\boldsymbol{x}},\boldsymbol{x},\boldsymbol{u}} ) = {\boldsymbol{C}_1}\boldsymbol{E}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ){)^{ - 1}}[{\boldsymbol{C}_1}( {\boldsymbol{A} - \boldsymbol{LC}} )\boldsymbol{e} + {\boldsymbol{C}_1}\boldsymbol{g}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ) - {\boldsymbol{C}_1}\boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ).
\end{equation}$$
From Assumption 2 and Equation (21), we conclude that
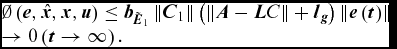 $$\begin{equation}
\begin{array}{l} \emptyset ( {\boldsymbol{e},\skew3\hat{\boldsymbol{x}},\boldsymbol{x},\boldsymbol{u}} ) \le {\boldsymbol{b}_{{{\tilde{\boldsymbol{E}}}_1}}}\left\| {{\boldsymbol{C}_1}} \right\|( {\left\| {\boldsymbol{A} - \boldsymbol{LC}} \right\| + {\boldsymbol{l}_\boldsymbol{g}}} )\left\| {\boldsymbol{e}( \boldsymbol{t} )} \right\|\\ \to 0( {\boldsymbol{t} \to \infty } ). \end{array}
\end{equation}$$
In order to appraise the fault signal f(t) from the sliding mode, the equivalent output error injection signal veq needs to be reconstructed. Using a low-pass filter for reconstructing this signal was proposed by Utkin et al in 1992. In this paper, the approach extended by Edwards(Reference Edwards, Spurgeon and Patton14) and yan(Reference Yan and Edwards32) will be used to appraise veq. From Assumption 2, the equivalent output error injection signal veq in Equation (25) can be approximated by
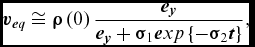 $$\begin{equation}
{\boldsymbol{v}_{\boldsymbol{eq}}} \cong \boldsymbol{\rho }( 0 )\frac{{{\boldsymbol{e}_\boldsymbol{y}}}}{{{\boldsymbol{e}_\boldsymbol{y}} + {\boldsymbol{\sigma }_1}\boldsymbol{exp}\left\{ { - {\boldsymbol{\sigma }_2}\boldsymbol{t}} \right\}}},
\end{equation}$$
where σ1 and σ2 are positive constants.
By defining
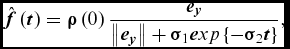 $$\begin{equation}
\skew5\hat\boldsymbol{f}( \boldsymbol{t} ) = \boldsymbol{\rho }( 0 )\frac{{{\boldsymbol{e}_\boldsymbol{y}}}}{{\left\| {{\boldsymbol{e}_\boldsymbol{y}}} \right\| + {\boldsymbol{\sigma }_1}\boldsymbol{exp}\left\{ { - {\boldsymbol{\sigma }_2}\boldsymbol{t}} \right\}}},
\end{equation}$$
and by inserting the approximation of veq from Equation (28) into Equation (16), we have
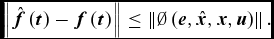 $$\begin{equation}
\left\| {\skew5\hat\boldsymbol{f}( \boldsymbol{t} ) - \boldsymbol{f}( \boldsymbol{t} )} \right\| \le \left\| {\emptyset ( {\boldsymbol{e},\skew3\hat{\boldsymbol{x}},\boldsymbol{x},\boldsymbol{u}} )} \right\|.
\end{equation}$$
Also, 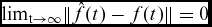 ${\lim }_{{\rm{t}} \to \infty } \| {\hat f{\rm{(}}t{\rm{)}} - f{\rm{(}}t{\rm{)}}} \| = 0$.
The parameters σ1 and σ2 in the above equation specify the degree to which an approximation to a perfect sliding mode is obtained. In the general case, σ1 is small and σ2 is large(Reference Edwards, Spurgeon and Patton14,Reference Yan and Edwards32) . Due to the numerical procedures used in the implementation of the algorithms, the error stays within a small bound ||e y|| ≤ ε around the sliding surface. In the majority of practical cases, a borderline is used to cope with the inordinate chattering and this also results in an approximated sliding surface.
7.0 ADVANTAGES OF THE PROPOSED METHOD
In the design of the proposed method, considerations have been made that have a prominent role in its practical implementation:
1. The proposed fault estimation approach is easy to implement and can be applied to a reasonably wide class of non-linear systems.
2. The proposed fault estimation/reconstruction signals are based only on the available plant input/output information and can be calculated online.
3. An actuator fault reconstruction instead of just detection is presented based on the equivalent output error injection signal.
4. This proposed method is free of undesirable chattering phenomena. Moreover, it can handle both structured and unstructured uncertainties.
5. Another benefit of the proposed fault estimation approach is its light burden of computations, which is an important figure in practical implementation and online control cases.
6. Since the integral of the system states is not used in dynamic equations of the sliding surface, the wind-up effect will not occur in the implementation of this method.
7. To design the proposed method of fault detection in Ref. Reference Yan and Edwards32, a transformation matrix is used to change system space. Their proposed methods for obtaining this transformation matrix were very complicated and time consuming in terms of implementation. In our paper, to overcome these difficulties, some strategies are presented that make the transfer matrix computationally efficient.
8.0 APPLICATION TO AN HIRM AIRCRAFT SYSTEM
Consider the simplified dynamics of the HIRM aircraft at the trim values Mach: 0.8, Height: 5000 ft(Reference Magni, Bennani and Terlouw33-Reference Yan and Edwards35). By reordering the system state variables
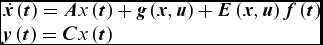 $$\begin{equation*}
\begin{array}{l} \skew4\dot{\boldsymbol{x}}( \boldsymbol{t} ) = \boldsymbol{Ax}( \boldsymbol{t} ) + \boldsymbol{g}( {\boldsymbol{x},\boldsymbol{u}} ) + \boldsymbol{E}( {\boldsymbol{x},\boldsymbol{u}} )\boldsymbol{f}( \boldsymbol{t} )\\ \boldsymbol{y}( \boldsymbol{t} ) = \boldsymbol{Cx}( \boldsymbol{t} ) \end{array}
\end{equation*}$$
 $$\begin{equation*}
A = \left[ {\begin{array}{*{20}{c}} 0&\quad 0&\quad 0&\quad 1\\ { - 0.367}&\quad { - 0.0318}&\quad {0.0831}&\quad { - 0.0008}\\ 0&\quad { - 0.0716}&\quad { - 1.4850}&\quad {0.9848}\\ 0&\quad { - 0.2797}&\quad { - 5.6725}&\quad { - 1.0253} \end{array}} \right]
\end{equation*}$$
 $$\begin{equation*}
g(x,u) = \left[ {\begin{array}{*{20}{c}} 0\\ 0\\ {\frac{{{F_e}}}{M}\Big({\raise0.7ex\hbox{${Sin{x_3}}$} \!\mathord{\left/ {\vphantom {{Sin{x_3}} {1 + {x_2}}}}\right.\kern-\nulldelimiterspace} \!\lower0.7ex\hbox{${1 + {x_2}}$}}\Big)}\\ 0 \end{array}} \right]
\end{equation*}$$
 $$\begin{equation*}
C = \left[ {\begin{array}{*{20}{c}} {\begin{array}{*{20}{c}} {\begin{array}{*{20}{c}} 1&\quad 0 \end{array}}&\quad 0&\quad 0 \end{array}}\\ {\begin{array}{*{20}{c}} 0&\quad 0&\quad 0&\quad 1 \end{array}} \end{array}} \right]\;{\rm{and}}\;E = \left[ {\begin{array}{*{20}{c}} {{\mu _1}}\\ {{\mu _2}}\\ {{\mu _3}}\\ {{\mu _4}} \end{array}} \right],
\end{equation*}$$
where the parameters Fe and M are the engine thrust and the aircraft mass, respectively. This system has four states x = col(x1, x2, x3, x4): pitch angle (rad); normalised airspeed deviation (v-v0)/v0 with v and v0 = 267.51 the present airspeed (m/s) and the favourable airspeed (m/s), respectively; angle-of-attack (rad); and pitch rate (rad/s). The fault distribution matrix E is dependent on the system dynamics and is known a priori. The representation μ1, μ2, …, μ4 is adopted for the purpose of comparison with the method in(Reference Yan and Edwards32).
It is clear that the fault signal is observable through output y1, so C1 = [1 0 0 0]. The other output is y2 = x4. The following form of observer, with one robust term, can be developed based on Equation (2).
 $$\begin{equation*}
\begin{array}{l}
{\skew3\hat{\boldsymbol{x}}}= \boldsymbol{A\hat x} + \boldsymbol{g}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ) + \boldsymbol{L}( {\boldsymbol{y} - \boldsymbol{C\hat x}} ) + \boldsymbol{E}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} )\boldsymbol{v}( \boldsymbol{t} )\\
\boldsymbol{v}( \boldsymbol{t} ) = - {({\boldsymbol{C}_1}\boldsymbol{E}( {\skew3\hat{\boldsymbol{x}},\boldsymbol{u}} ))^{ - 1}}\boldsymbol{\rho }( 0 )\boldsymbol{sign}( {{\boldsymbol{C}_1}\skew3\hat{\boldsymbol{x}} - {\boldsymbol{C}_1}\boldsymbol{x}} ),
\end{array}
\end{equation*}$$
where 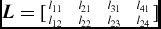 $\boldsymbol{L} = [\fontsize{6}{8}{\selectfont
\textstyle\begin{array}{llll}
\textstyle{{{{l}}_{11}}}&{{{{l}}_{21}}}&{{{{l}}_{31}}}&{{{{l}}_{41}}} \\
\textstyle {{{{l}}_{12}}}&{{{{l}}_{22}}}&{{{{l}}_{23}}}&{{{{l}}_{24}}}
\end{array}}]$ is the feedback gain in the sliding mode of
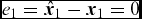 ${e_1} = {\skew3\hat{\boldsymbol{x}}_1} - {\boldsymbol{x}_1} = 0$. The unknown fault can be recovered from the sliding mode based on Equation (29) as
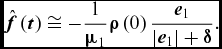 $$\begin{equation}
\skew5\hat\boldsymbol{f}( \boldsymbol{t} ) \cong - \frac{1}{{{\boldsymbol{\mu }_1}}}\boldsymbol{\rho }( 0 )\frac{{{\boldsymbol{e}_1}}}{{\left| {{\boldsymbol{e}_1}} \right| + \boldsymbol{\delta }}}.
\end{equation}$$
9.0 SIMULATION RESULTS
To demonstrate the performance of the proposed method, simulations are presented in two stages.
Simulation 1: In this section, we try to design our proposed SMO for estimating the system's states. The fault distribution vector elements are selected to be μ1 = 1.2, μ2 = 0.6, μ3 = 0.2, μ4 = 0.7. The sliding-mode gain is selected to be ρ(.) = 8. The initial conditions for the plant and estimator are set as x(0) = [6 3 6 2] and 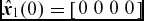 ${\skew3\hat{\boldsymbol{x}}_1}(0) = [\begin{array}{*{20}{c}} 0&0&0&0 \end{array}]$, respectively. For the recovery of the unknown input from the sliding mode, the parameter δ in Equation (31) is selected to be 0.015. The gain is developed in a way that the reduced-order system is stable. We chose the feedback gain
 $$\begin{equation*}
\boldsymbol{L} = {\left[ {\begin{array}{*{20}{c}} {\begin{array}{*{20}{c}} {1.701}&\quad {0.78}&\quad {1.6}&\quad {0.19} \end{array}}\\ {\begin{array}{*{20}{c}} {0.09}&\quad { - 4.65}&\quad { - 4.85}&\quad 6 \end{array}} \end{array}} \right]^T}.
\end{equation*}$$
The positive-definite matrix P that fulfils the algebraic Ricatti equation (ARE) (28) is obtained to be
 $$\begin{equation*}
\boldsymbol{P} = \left[ {\begin{array}{*{20}{c}} {\begin{array}{*{20}{c}} {0.2494}&\quad {0.3476}&\quad {0.1970} \end{array}}\\ {\begin{array}{*{20}{c}} {0.4016}&\quad {1.9341}&\quad {0.8199} \end{array}}\\ {\begin{array}{*{20}{c}} {0.2397}&\quad {0.2497}&\quad {2.0091} \end{array}} \end{array}} \right],
\end{equation*}$$
with λmax(Q) = 1.9921. The Lipschitz constant for the selected values was computed to be l Φ = 0.201. Now, we can investigate if the condition in Remark 3 is fulfilled.
To verify the estimation integrity in the existence of high frequency elements, we recommend a square wave disturbance of amplitude 1 and period 6.66 s. Simulation results for the state estimation with the non-linear SMO are shown in Figs 1–4. In spite of the existence of a large unknown input/disturbance, leading to large oscillations in the HIRM aircraft, the observer was capable of tracking the states.
The first state of the system and the observer with a sliding-mode term.

The second state of the system and the observer with a sliding-mode term.
The third state of the system and the observer with a sliding-mode term.
The fourth state of the system and the observer with a sliding-mode term.
Simulation 2: In this stage, a fault estimator based on the proposed SMO of Yan et al (2007) is designed for an HIRM aircraft system. Then, the performance of the proposed method is compared with that of the SMO presented by Yan et al (2007) to show the superiority of the proposed method. It should be noted that the design parameters of the proposed method are the same as those in the first stage of simulation. It can be concluded from Fig. 5 that the proposed observer has estimated the fault efficiently. However, the SMO of Yan et al (2007) shows chattering and is not highly accurate. By changing the fault, as shown in Fig. 6 to verify the robustness of the suggested procedure, we selected 6sin(0.6πt)–3cos(0.35πt) as a fault signal. It can be observed that the performance of the proposed method is still acceptable. Although the SMO of Yan et al (2007) does not have chattering, it has a high estimation error making its implementation problematic.
A fault and its estimation (first example).
A fault and its estimation (second example).
10.0 CONCLUSION
This study aims to propose a simple SMO developed for accurate state estimation in the presence of faults for a class of non-linear systems. The proposed method is simple and is of a relatively lower complexity compared to existing methods. Robust terms are designed in a way that faults can be reconstructed directly from the sliding surfaces. Our proposed method does not need a non-linear transformation. The stability of the reduced-order error system in the sliding mode is established. A specific HIRM aircraft system example is given to illustrate the efficiency of the proposed approach. Since most industrial systems are uncertain and non-linear, extension of the proposed method to robust fault diagnosis for uncertain non-linear systems is another interesting issue.



