Nomenclature
- LOS
-
line of sight
- ESO
-
extended state observer
- HIL
-
hardware in the loop
- SMC
-
sliding mode control
- RCGL
-
robust cooperative guidance law
- DCGL
-
distributed cooperative guidance law
Greek symbol
-
 $G$
-
graph of network
-
$N$
-
collection of missiles
-
$\zeta $
-
set of edges
-
$A$
-
adjacency matrix
-
${q_\varepsilon }$
-
elevation angle of LOS
-
${q_\beta }$
-
azimuth angle of LOS
-
${\bar q_\varepsilon }$
-
desired elevation angle of LOS
-
${\bar q_\beta }$
-
desired azimuth angle of LOS
-
${r_i}$
-
range between
$i$
-th missile and the target -
$V_{los}^i$
-
velocity of the
$i$
-th missile in LOS frame -
$a_{los}^i$
-
acceleration of the
$i$
-th missile in LOS frame -
${t_{go,i}}$
-
time-to-go of the
$i$
-th missile -
${t_{f,i}}$
-
impact time of the
$i$
-th missile -
$P_c^i$
-
thrust command of the
$i$
-th missile -
$t_{fal}^i$
-
fault occurrence time of the
$i$
-th missile -
$k_{fal}^i$
-
thrust gain coefficient of the
$i$
-th missile -
${\mathrm{\Delta }}_p^i$
-
thrust deviation coefficient of the
$i$
-th missile -
${\tilde u_{x,i}}$
-
virtual control instruction of the
$i$
-th missile -
$\tilde d_x^i$
,
$\tilde d_y^i$
,
$\tilde d_z^i$
-
disturbance in LOS frame of the
$i$
-th missile


1.0 Introduction
Recently, the coordinated work of multiple unmanned systems has garnered widespread attention due to its potential military and economic value [Reference Zhang and Jiahao1]. In the military field, compared with a single missile, multiple missiles can effectively enhance the attack effectiveness by striking key targets in coordination. Furthermore, the coordination of multiple missiles can enhance the reliability of the combat system. The simultaneous arrival of missiles from different directions at the target area can exert more pressure on the defense system, thereby increasing the probability of breakthrough [Reference Jeon, Lee and Tahk2, Reference Zhou and Yang3]. Research on cooperative guidance laws is crucial to ensuring the reliable coordination of multiple missiles [Reference Li and Ding4, Reference Wang, Ding, Wang and Shan5].
Many scholars have conducted related work [Reference Chen, Chen, Liu and Cheng6, Reference Dong, Wang, Liu, Wang and Xin7]. Reference (Reference Sinha, Kumar and Mukherjee8) researched simultaneous interception tasks involving a class of missiles with canards. They designed a coordinated guidance control integrated strategy and explored two coordinated schemes, one with leaders and one without. Addressing the challenge of multi-missile three-dimensional simultaneous attacks on manoeuvering targets with angle constraints, Ref. (Reference Dong, Wang, Wang, Zuo and Shan9) developed a distributed cooperative protocol and integral sliding manifold guidance law. They utilised a fixed-time observer to observe and compensate for the unknown manoeuvers of the target. For simultaneous attacks under directed communication topology, Ref. (Reference Lyu, Guo, Li, Ma and Zhang10) designed a new cooperative guidance law, ensuring that multiple missiles reach the target area simultaneously, and the relative line-of-sight (LOS) angle between the missiles converges to the expected value. Reference (Reference Kim, Cho and Kim11) proposed a sliding mode guidance law that does not require explicit time-to-go estimation, showing superior performance in engaging non-stationary targets.
To apply the cooperative guidance algorithm in practice, it is crucial to consider factors such as communication delays, switching of communication topologies, limitations in the field of view of the seekers, and actuator saturation. Reference (Reference Yu, Dai, Li, Zou, Ma, Ma and Zhang12) proposed a distributed fixed-time convergence guidance law based on proportional guidance to address the challenges of input delay and topology switching in multi-missile cooperative systems. Reference (Reference Huang, Yu, Dong, Li and Ren13) conducted research on coordinated strikes of multiple missiles on manoeuvering targets under time and angle constraints, developing an exponential convergence state observer and an extended state observer (ESO) to observe target manoeuvering information. Reference (Reference Hou, Lan, Chen and Zhuang14) investigated finite-time coordinated strikes of multiple missiles under angle constraints and switching communication topologies using terminal sliding mode control (SMC) technology. They derived stability conditions for the communication network during connectivity and disconnection switches. However, achieving a balance between fast convergence and bounded inputs necessitates further in-depth research.
In addition, in complex battlefield environments, if some missiles in the cooperative system fail or are destroyed, the fault signal can propagate through the cooperative system, potentially compromising the entire mission [Reference Chen, Huang, Wang, Jiang, Cheng and Yang15, Reference Yu, Zhang, Qu, Su, Zhang and Xing16]. Therefore, considering scenarios such as aircraft damage or actuator failure is crucial to enhance the reliability of cooperative systems. Fault-tolerant control represents an effective approach for managing actuator failures and has been extensively utilised in single-machine anti-jamming fault-tolerant control systems [Reference Zhao, Song, Ai, Xu and Liu17]. In recent years, cooperative fault-tolerant control methods have also received considerable attention [Reference Yang, Jiang, Yang and Liu18].
Reference (Reference Kamel, Ghamry and Zhang19) equivalently transformed the formation fault-tolerant control problem into an optimal allocation problem and considered two types of faults, mild and severe, to reassign tasks for cooperative formation control. Reference (Reference Yu, Liu and Zhang20) considered the health of the entire system to generate executable reference trajectories and used redundant actuators to compensate for the effects of faulty actuators. Reference (Reference Li, Wu and Xu21) proposed a fixed-time fault-tolerant cooperative guidance law to achieve simultaneous attacks on targets under actuator failure without relying on fault diagnosis and identification modules. Reference (Reference Wang, Ding, Wang and Shan5) introduced a robust three-dimensional cooperative guidance law, incorporating a local filter to isolate faulty aircraft and ensure simultaneous target hits by the remaining missiles. Reference (Reference Liu, Zhang, Jiang and Yan22) designed a fault-tolerant controller using an adaptive update mechanism and boundary layer theory to constrain the formation system error in case of faults. Reference (Reference Yu, Zhang, Jiang, Su, Fu, Jin and Chai23) proposed a fractional-order PID-based cooperative fault-tolerant control system for networked unmanned aerial vehicle coordination, addressing actuator failure and wind disturbances with low-pass filters and recursive neural networks. Reference (Reference Liu, Liu and Xi24) developed a fully distributed adaptive fault-tolerant formation control method for multi-octocopter unmanned aerial vehicles under uncertainties and actuator failures. Reference (Reference Yu, Qu and Zhang25) researched coordinated control of multiple unmanned aerial vehicle systems under actuator failures and saturation, employing an observer to detect total disturbances and compensating them in a dynamic surface controller. An auxiliary dynamic system was also introduced to prevent prolonged saturation of the controller.
While the guidance control technology of multi-intelligent systems has been extensively researched, existing literature predominantly focuses on designing fault-tolerant guidance laws for the inner loop of distributed systems. In these studies, fault isolation typically addresses the kinematics of the outer loop, lacking comprehensive fault tolerance and reconstruction capabilities. Few investigations simultaneously address cooperative fault-tolerant control for both the inner and outer loops of distributed systems [Reference Ziquan, Zhang, Jiang, Jun and Ying26]. Therefore, there is a critical need to extend the extensively explored inner loop cooperative fault-tolerant control to encompass the kinematics of the outer loop, especially in scenarios involving potential aircraft failures.
Motivated by this gap, this paper proposes a robust cooperative guidance approach for distributed multi-missile systems, specifically addressing challenges posed by actuator saturation and thruster failures. The primary contributions of this study are outlined as follows:
-
1. Compared to Ref. (Reference Yang and Song27), the guidance law presented in this paper shows enhanced robustness to disturbances and uncertainties by incorporating a state observer. This improvement allows for coordinated strikes on manoeuvering targets under various disruptive conditions. Additionally, in contrast to Ref. (Reference Yu, Dai, Li, Zou, Ma, Ma and Zhang28), the proposed guidance law considers impact angle constraints, facilitating spatiotemporal coordinated strikes and enhancing regional blockade capabilities. Importantly, this paper not only theoretically establishes the finite-time convergence characteristics of the proposed algorithm but also demonstrates its real-time performance and robustness through hardware-in-the-loop (HIL) experiments.
-
2. While Refs (Reference Song, Song and Xu29, Reference Chen, Chen, Liu and Cheng6) addressed the simultaneous strike problem under impact angle constraints, they either neglected to consider actuator saturation or implemented constraints that were lenient. Recognising the limitations imposed by actual aircraft capabilities, a nonlinear sliding surface is designed to ensure convergence time and spatiotemporal coordination under strict actuator constraints.
-
3. In Ref. (Reference Li and Ding4), isolation is achieved solely through a fault filter to prevent the fault from spreading within the system. Conversely, in Ref. (Reference Hu, Niu, Carrasco, Lennox and Arvin30), fault tolerance of the formation is managed by redistributing tasks when formation members are lost. Despite the effectiveness of these methods, the full utilisation of faulty aircraft remains unrealised. This paper introduces a robust cooperative guidance law (RCGL). By reconstructing the guidance law, the remaining healthy aircraft adjust their manoeuvers to accommodate the aircraft with the thrust failure. The cooperative strategy is redefined, enabling the execution of coordinated spatiotemporal strikes.
This paper is structured as follows: Section 2 introduces necessary preliminary knowledge and establishes the relative kinematic equations between the missiles and the target. In Section 3, the robust cooperative guidance law is proposed, and its convergence characteristics are analysed theoretically. Section 4 presents simulation results under different scenarios and includes HIL experiment outcomes. Finally, Section 5 discusses the effectiveness and advancements of the proposed algorithms.
2.0 Preliminaries and problem formulation
2.1 Preliminaries
In multi-agent systems, the communication topology among the agents is represented by the graph
 $G\left( {N,\zeta, A} \right)$
, where
 $N = \left\{ {{N_1},{N_2},{N_3}, \ldots } \right\}$
denotes the set of all nodes, symbolising the collection of missiles. Here,
 $\zeta $
represents the edges, and
 $A = \left[ {{a_{ij}}} \right] \in {\mathbb{R}^{n \times n}}$
is the adjacency matrix. If the
 $i$
-th agent can receive information from the
 $j$
-th agent, then
 ${a_{ij}} = 1$
; otherwise,
 ${a_{ij}} = 0$
, with the specific condition
 ${a_{ii}} = 0$
.
Consider nonlinear system
 \begin{align} {\dot x_b}\left( t \right) = f\left( {{x_b}\left( t \right)} \right)\!,\ f\!\left( 0 \right) = 0,{x_b}\left( t \right) \in {\mathbb{R}^n} \end{align}
where
 ${x_b} = 0$
is an equilibrium point for the nonlinear function
 $f\,:\,{\mathbb{R}^n} \to {\mathbb{R}^n}$
.
Definition 1.
If the nonlinear system described in Equation (1) is globally asymptotically stable, and every state can reach the equilibrium point within a finite time, the equilibrium point is termed finite-time stable. Specifically, for
 $t \geqslant {t^*},x\left( t \right) = {x^*}$
(Reference Utkin31).
Lemma 1.
Suppose there exists a positive definite function
 ${V_b}\left( {{x_b}\left( t \right)} \right)$
, which satisfies the inequality
 \begin{align} {\dot V_b}\left( {{x_b}\left( t \right)} \right) \le - {\tau _1}{V_b}\left( {{x_b}\left( t \right)} \right) - {\tau _2}{V_b}{({x_b}\left( t \right))^\theta }, \end{align}
where
 ${\tau _1} \gt 0,{\tau _2} \gt 0,0 \lt \theta \lt 1$
.
Then the system converges in finite time, and the upper bound of the setting-time
 \begin{align} \le \frac{1}{{{\tau _1}\left( {1 - \theta } \right)}}{\mathrm{ln}}\frac{{{\tau _1}V_b^{1 - \theta }\left( {{x_b}\left( {{t_0}} \right)} \right) + {\tau _2}}}{{{\tau _2}}}, \end{align}
where
 ${V_b}\left( {{x_b}\left( {{t_0}} \right)} \right)$
is the initial value of the Lyapunov function
 ${V_b}\left( {{x_b}\left( t \right)} \right)$
[Reference Bhat and Bernstein32, Reference Orlov33].
Lemma 2.
Consider a first-order multi-agent system with
 $n$
individuals, where
 $\dot x = u$
. When the communication topology network graph
 $G$
is undirected and connected, the consensus protocol
 \begin{align} {u_i} = {\mathrm{sign}}\left( {\mathop \sum \limits_{j = 1}^n {c_{ij}}\left( {{x_j} - {x_i}} \right)} \right){\left| {\mathop \sum \limits_{j = 1}^n {c_{ij}}\left( {{x_j} - {x_i}} \right)} \right|^{{\alpha _1}}}, \end{align}
solves the finite-time consistency problem of the multi-agent system, where
 $0 \lt {\alpha _1} \lt 1$
, and
 $sign\left( - \right)\,:\,{\mathbb{R}^n} \to {\mathbb{R}^n}$
is a sign function [Reference Wang and Xiao34].
Lemma 3.
If a constant
 $\mu $
satisfies the inequality
 \begin{align} f\left( {{x_i},t} \right) - f{\left( {{x_0},t} \right)_2} \le \mu {x_i} - {x_0}_2^\alpha, \end{align}
where
 $i \in N$
, the nonlinear function is
 $\alpha - H\ddot older$
continuity, where
 $0 \lt \alpha \lt 1$
[Reference Hölder35].
Remark 1. It is commonly assumed that the nonlinear function
 $f$
satisfies Lipschitz continuity. However, if
 $0 \lt \alpha \lt \gamma \lt 1$
, all
 ${C^{0,\gamma }}\left( {{R^n}} \right)$
 $H\ddot older$
continuous functions are also
 ${C^{0,\alpha }}\left( {{R^n}} \right)$
 $H\ddot older$
continuous [Reference He, Liu, Lu, Liu and Du36]. Therefore, for the generality of this paper, it is appropriate to assume that the function
 $f$
is
 $\alpha - H\ddot older$
continuous.
2.2 Problem formulation
Figure 1 illustrates the scenario of multiple missiles coordinating to strike a manoeuvering target. The inertial coordinate system used in this paper is the North-Up-East coordinate system, with the Y-axis perpendicular to the horizontal plane and upward, expressed as
 ${O^I}{x^I}{y^I}{z^I}$
.
 ${O^L}{x^L}{y^L}{z^L}$
represents the LOS coordinate system.
 ${q_\varepsilon }$
denotes the elevation angle of the LOS,
 ${q_\beta }$
represents the azimuth angle.
Schematic diagram of three-dimensional coordinated strike.

According to the Coriolis theorem, the following equations can be derived as follows:
 \begin{align} {\bf{V}}_{los}^i = \frac{{\partial {{\bf{R}}_i}}}{{\partial t}} + {{\bf{\Omega }}_i} \times {{\bf{R}}_i} \end{align}
 \begin{align} {\bf{a}}_{los}^i = \frac{{\partial {\bf{V}}_{los}^i}}{{\partial t}} + {{\bf{\Omega }}_i} \times {\bf{V}}_{los}^i \\[6pt] \nonumber \end{align}
where
 ${{\bf{R}}_i} = {[{r_i},0,0]^T}$
,
 ${\bf{\Omega }} = {[{\dot q_{\beta, i}}{\mathrm{sin}}{q_{\varepsilon,i}},{\dot q_{\beta, i}}{\mathrm{cos}}{q_{\varepsilon, i}},{\dot q_{\varepsilon, i}}]^T}$
represents the angular velocity vector of the LOS coordinate system with respect to the inertial coordinate system.
 ${\bf{a}}_{los}^i = {{\bf{a}}_T} - {\bf{a}}_M^i + {\bf{d}}_{los}^i$
denotes the acceleration vectors in the LOS coordinate system.
 ${{\bf{a}}_T} = {[{a_{Tx}},{a_{Ty}},{a_{Tz}}]^T}$
,
 ${\bf{a}}_M^i = {[a_{Mx}^i,a_{My}^i,a_{Mz}^i]^T}$
represent the accelerations of the
 $i$
-th missile and the target in the LOS, respectively.
 ${\bf{d}}_{los}^i = {[d_x^i,d_y^i,d_z^i]^T}$
stands for the perturbation caused by unmodeled dynamics. Thus, Equations (6) and (7) can be derived as:
 \begin{align} V_{los}^i = \left[ {\begin{array}{c}{{{\dot r}_i}}\\{{r_i}{{\dot q}_{\varepsilon, i}}}\\{ - {r_i}{{\dot q}_{\beta, i}}{\mathrm{cos}}{q_{\varepsilon, i}}}\\{}\end{array}} \right] \end{align}
 \begin{align} a_{los}^i & = \left[ {\begin{array}{c}{{{\ddot r}_i}}\\[3pt] {{{\dot r}_i}{{\dot q}_{\varepsilon, i}} + {r_i}{{\ddot q}_{\varepsilon, i}}}\\[3pt] { - {r_i}{{\ddot q}_{\beta, i}}{\mathrm{cos}}{q_{\varepsilon, i}} - {{\dot r}_i}{{\dot q}_{\beta, i}}{\mathrm{cos}}{q_{\varepsilon, i}} + {r_i}{{\dot q}_{\beta, i}}{{\dot q}_{\varepsilon, i}}{\mathrm{sin}}{q_{\varepsilon, i}}}\\[3pt] {}\end{array}} \right] + \left[ {\begin{array}{c}{{{\dot q}_{\beta, i}}{\mathrm{sin}}{q_{\varepsilon, i}}}\\[3pt] {{{\dot q}_{\beta, i}}{\mathrm{cos}}{q_{\varepsilon, i}}}\\[3pt] {{{\dot q}_{\varepsilon, i}}}\\[3pt] {}\end{array}} \right] \times \left[ {\begin{array}{c}{{{\dot r}_i}}\\[3pt] {{r_i}{{\dot q}_{\varepsilon, i}}}\\[3pt] { - {r_i}{{\dot q}_{\beta, i}}{\mathrm{cos}}{q_{\varepsilon, i}}}\\[3pt] {}\end{array}} \right] \nonumber \\[3pt] & = \left[ {\begin{array}{*{20}{l}}{{{\ddot r}_i} - {r_i}\dot q_{\varepsilon, i}^2 - {r_i}\dot q_{\beta, i}^2{\mathrm{cos}}{q_{\varepsilon, i}}}\\[3pt] {2{{\dot r}_i}{{\dot q}_{\varepsilon, i}} + {r_i}{{\ddot q}_{\varepsilon, i}} + {r_i}{{\dot q}^2}_{\beta, i}{\mathrm{sin}}{q_{\varepsilon, i}}{\mathrm{cos}}{q_{\varepsilon, i}}}\\[3pt] { - 2{{\dot r}_i}{{\dot q}_{\beta, i}}{\mathrm{cos}}{q_{\varepsilon, i}} + 2{r_i}{{\dot q}_{\beta, i}}{{\dot q}_{\varepsilon, i}}{\mathrm{sin}}{q_{\varepsilon, i}} - {r_i}{{\ddot q}_{\beta, i}}{\mathrm{cos}}{q_{\varepsilon, i}}}\\[3pt] {}\end{array}} \right] \end{align}
Remark 2. In the actual strike process, the relative speed change between the missile and the target is small in the LOS direction. Assuming that both the missiles and the target exhibit weak manoeuvers, it can be reasonably assumed that
 $\dot r \lt 0$
holds [Reference Zhou and Yang3]. Consequently, the remaining flight time can be expressed as
 ${t_{go,i}} = - {r_i}/{\dot r_i}$
.
The derivative of the remaining flight time can be derived as follows.
 \begin{align} {\dot t_{go,i}} = - 1 + \frac{{{r_i}{{\ddot r}_i}}}{{{{\dot r}_i}^2}} \end{align}
The state variables of the system are then defined as
 ${x_1} = {r_i},{x_2} = {\dot r_i},{x_3} = {e_{{q_{\varepsilon, i}}}},{x_4} = {e_{{q_{\beta, i}}}},{x_5} = {\dot e_{{q_{\varepsilon, i}}}}, {x_6} = {\dot e_{{q_{\beta, i}}}}$
, where
 ${e_{{q_{\varepsilon, i}}}} = {q_{\varepsilon, i}} - {\bar q_{\varepsilon, i}}$
and
 ${e_{{q_{\beta, i}}}} = {q_{\beta, i}} - {\bar q_{\beta, i}}$
are the errors of the elevation and azimuth angle of LOS, respectively.
 ${\bar q_{\varepsilon, i}}$
and
 ${\bar q_{\beta, i}}$
are the desired elevation and azimuth angle, respectively, assumed to be constant. Therefore, the three-dimensional guidance system can be described as:
 \begin{align} \left\{ {\begin{array}{l}{{{\dot x}_1} = {x_2}}\\[3pt] {{{\dot x}_2} = {a_{Tx}} - a_{Mx}^i + {x_1}x_5^2 + {x_1}x_6^2{\mathrm{co}}{{\mathrm{s}}^2}{q_{\varepsilon, i}} + d_x^i}\\[3pt] {{{\dot x}_3} = {x_5}}\\[3pt] {{{\dot x}_4} = {x_6}}\\[3pt] {{{\dot x}_5} = \frac{1}{{{x_1}}}\left[ {{a_{Ty}} - a_{My}^i - 2{x_2}{x_5} - {x_1}x_6^2{\mathrm{sin}}{q_{\varepsilon, i}}{\mathrm{cos}}{q_{\varepsilon, i}} + d_y^i} \right]}\\[3pt] {{{\dot x}_6} = 2{x_5}{x_6}{\mathrm{tan}}{q_{\varepsilon, i}} + \left( {a_{Mz}^i - {a_{Tz}} - d_z^i} \right)/\left( {{x_1}{\mathrm{cos}}{q_{\varepsilon, i}}} \right) - 2{x_2}{x_6}/{x_1}}\\[3pt] {{{\dot x}_7} = - 1 + {x_1}/x_2^2\left[ {{a_{Tx}} - a_{Mx}^i + {x_1}x_5^2 + {x_1}x_6^2{\mathrm{co}}{{\mathrm{s}}^2}{q_{\varepsilon, i}} + d_x^i} \right]}\end{array}} \right. \end{align}
where
 ${q_{\varepsilon, i}} = {x_3} + {\bar q_{\varepsilon, i}}$
.
Considering the thruster failure of a missile in practice, the mathematical model of the failure can be expressed as follows [Reference Akmal, Yusoff and Arshad37]:
 \begin{align} {P_i} = \begin{cases}{P_c^i} & {}{0 \lt t \le t_{fal}^i}\\[3pt] {k_{fal}^iP_c^i + {\mathrm{\Delta }}_p^i} & {}{t_{fal}^i \lt t} \end{cases} \end{align}
where
 $P_c^i$
is the thrust command,
 $t_{fal}^i$
is the fault occurrence time,
 $k_{fal}^i$
is the thrust gain coefficient, and
 ${\mathrm{\Delta }}_p^i$
is the thrust deviation coefficient.
3.0 Cooperative guidance laws
In this section, a three-dimensional nonlinear cooperative guidance law is developed to achieve spatiotemporal coordinated strikes by multiple missiles on a manoeuvering target under stringent input saturation. Additionally, the potential impact of thruster failure is considered, to formulate a RCGL.
3.1 Guidance law in the LOS direction
The guidance law in the LOS direction is designed to achieve simultaneous attack. First, the missile arrival time
 ${t_{f,i}} = t + {t_{go,i}}$
is defined.
To further simplify, a virtual control instruction is designed
 \begin{align} {\tilde u_{x,i}} = \frac{{x_1^2x_5^2}}{{x_2^2}} - \frac{{{x_1}a_{Mx}^i}}{{x_2^2}} + \frac{{x_1^2x_6^2{\mathrm{co}}{{\mathrm{s}}^2}\left( {{x_3} + {{\bar q}_{\varepsilon, i}}} \right)}}{{x_2^2}}. \end{align}
In that way,
 \begin{align} {\dot t_{f,i}} = {\tilde u_{x,i}} + \tilde d_x^i, \end{align}
where
 $\tilde d_x^i = {x_1}\left( {{a_{Tx}} + d_x^i} \right)/x_2^2$
represents the disturbance caused by manoeuver of the target and unmodeled dynamics.
Drawing upon the first-order system described in Equation (14) and leveraging the standard finite-time consensus protocol from Lemma 2, the following robust guidance law is formulated.
 \begin{align} {u_i}\left( t \right) = \beta \mathop \sum \limits_{j \in {{\mathcal{N}}_i}} {a_{ij}}{\mathrm{sign}}{\left( {{x_j}\left( t \right) - {x_i}\left( t \right)} \right)^\gamma } - {d_i}{\mathrm{sign}}{\left( {{x_i}\left( t \right) - {x_0}\left( t \right)} \right)^\alpha } \end{align}
where
 $0 \lt \gamma \le 1,0 \lt \alpha \lt 1,{d_i} \in \left\{ {0,1} \right\}$
. In addition,
 ${\mathrm{sign}}{\left( x \right)^\gamma } = |x{|^\gamma }{\mathrm{sign}}\left( x \right)$
.
As illustrated in Fig. 2, when the system has no actuator faults,
 ${d_i} = 0$
, it represents a fully distributed system. However, in the case of thruster failure, a leader is designated to implement the cooperative guidance law using a leader-follower approach, which takes into account the reduced manoeuverability resulting from the thruster failure.
Robust nonlinear cooperative guidance law.

Theorem 1. Consider the guidance subsystem modeled by Equation (14), if the consensus protocol is designed as Equation (15), then the distributed system converges in finite time.
Proof. When
 ${d_i} = 0$
, as indicated by Lemma 2, this distributed system converges in finite time.
When
 ${d_i} \ne 0,\gamma = 1$
,
 \begin{align} {u_i}\left( t \right) = \beta \mathop \sum \limits_{j \in {{\mathcal{N}}_i}} {a_{ij}}{\mathrm{sign}}\left( {{x_j}\left( t \right) - {x_i}\left( t \right)} \right) - {d_i}{\mathrm{sign}}{\left( {{x_i}\left( t \right) - {x_0}\left( t \right)} \right)^\alpha }, \end{align}
where
 ${x_0}$
is the leader.
Assume the system is
 ${\dot x_i} = f\left( {{x_i}\left( t \right),t} \right) + {u_i}\left( t \right)$
, and
 ${\dot x_0} = f\left( {{x_0}\left( t \right),t} \right)$
. Define
 \begin{align} {e_i}\left( t \right) = {x_i}\left( t \right) - {x_0}\left( t \right)\!,{\mathrm{\;\;\;\;}}i \in N, \end{align}
then
 \begin{align} {\dot e_i}\left( t \right) = f\left( {{x_i}(t),t} \right) - f\left( {{x_0}(t),t} \right) + {u_i},{\mathrm{\;\;\;\;}}i \in N. \end{align}
According the Lemma 3,
 \begin{align} \Vert f\left( {{x_i},t} \right) - f{\left( {{x_0},t} \right)\Vert_2} \le \mu \Vert {x_i} - {x_0}\Vert_2^\alpha . \end{align}
Consider the Lyapunov function
 \begin{align} V\left( t \right) = \frac{1}{2}\mathop \sum \limits_{i = 1}^N e_i^T\left( t \right){e_i}\left( t \right), \end{align}
then
 \begin{align*} \dot V\left( t \right) & = \mathop \sum \limits_{i = 1}^N \,e_i^T{\dot e_i} \nonumber\\[3pt]& \le \mathop \sum \limits_{i = 1}^N \,\mu \Vert {e_i}\Vert^{1 + \alpha } - \beta {e^T}\left( {L \otimes {I_n}} \right)e - \mathop \sum \limits_{i = 1}^N \,{d_i}\Vert{e_i}\Vert^{1 + \alpha }\nonumber\\[3pt]\end{align*}\begin{align}&\le - {\left( {\mathop \sum \limits_{i = 1}^N {{\left( {{d_{{\mathrm{min}}}} - \mu } \right)}^{\frac{2}{{1 + \alpha }}}}\Vert{e_i}\Vert^2} \right)^{\frac{{1 + \alpha }}{2}}}\nonumber\\[3pt]& = - cV{(t)^{\frac{{1 + \alpha }}{2}}} \end{align}
where
 $e = {({e_1},{e_2}, \cdots, {e_N})^T}$
,
 $c = {2^{\frac{{1 + \alpha }}{2}}}\left( {{d_{{\mathrm{min}}}} - \mu } \right)$
, and
 $ \otimes $
denotes the Kronecker product. Thus, according to Lemma 1, it can be concluded that the system converges in finite time.
Therefore, whether it is a fully distributed system or a leader-follower system, the time-to-go will converge within a finite time. This completes the proof.
3.2 Guidance laws in the normal direction of LOS
In this subsection, finite-time guidance laws for both the elevation and azimuth directions of the LOS are designed and analysed to satisfy the attack angle constraint.
Design a nonlinear sliding surface,
 \begin{align} s = {x_5} - \left( {a/\left( {1 + {e^{k{x_3}}}} \right) - 0.5a} \right), \end{align}
and take the reaching law
 $\dot s = - {k_1}s - {k_2}{\mathrm{sign}}{(s)^\rho }$
. Thus,
 \begin{align} a_{My}^i = - 2{x_2}{x_5} - {x_1}x_6^2{\mathrm{sin}}{q_{\varepsilon, i}}{\mathrm{cos}}{q_{\varepsilon, i}} + {k_1}{x_1}s + {k_2}{x_1}{\mathrm{sign}}{(s)^\rho } + \frac{{ak{e^{k{x_3}}}{x_1}{x_5}}}{{{{(1 + {e^{k{x_3}}})}^2}}} + \tilde q_y^i \end{align}
where
 $\tilde d_y^i = \left( {{a_{Ty}} + d_y^i} \right)/{x_1}$
represents the disturbance caused by manoeuver of the target and unmodeled dynamic.
In the subsequent analysis, the finite-time convergence of the proposed guidance law will be demonstrated from two perspectives. Firstly, it will be established that reaching the sliding surface occurs in finite time. Secondly, it will be proven that the system converges to the equilibrium point exponentially.
Theorem 2. When employing the sliding mode guidance law as described in Equations (22) and (23) in the LOS elevation direction, the system can converge to the sliding surface in finite time, and the convergence from the sliding surface to the equilibrium state is exponential.
Proof. Considering the Lyapunov function
 ${V_1} = \frac{1}{2}{s^2}$
, its derivative can be derived as:
 \begin{align}{\dot V_1} & = s\dot s \nonumber\\[3pt]& = - {k_1}{s^2} - {k_2}|s{|^{\rho + 1}} \nonumber\\[3pt]& = - 2{k_1}{V_1} - {2^{\left( {\rho + 1} \right)/2}}{k_2}V_1^{\left( {\rho + 1} \right)/2}. \end{align}
Based on Lemma 1, it can be concluded that when the designed reaching law is employed, the system will converge to the sliding surface within a finite time. The upper limit of the convergence time depends on the initial state of the system.
 \begin{align} T \le \frac{1}{{2{k_1}\left( {\left( {1 - \rho } \right)/2} \right)}}{\mathrm{ln}}\frac{{2{k_1}V_1^{\left( {1 - \rho } \right)/2}\left( 0 \right) + {2^{\left( {\rho + 1} \right)/2}}{k_2}}}{{{2^{\left( {\rho + 1} \right)/2}}{k_2}}} \end{align}
Next, the convergence process from the sliding surface to the equilibrium state is analysed. When the system slides on the sliding surface,
 $s = 0$
, which means
 \begin{align} {x_5} = a/\left( {1 + {e^{k{x_3}}}} \right) - 0.5a \end{align}
Considering the Lyapunov function
 ${V_2} = \frac{1}{2}x_3^2$
, its derivative can be derived as:
 \begin{align} {\dot V_2} &= {x_3}{\dot x_3} \nonumber\\[3pt]&= a{x_3}\left( {\frac{1}{{1 + {e^{k{x_3}}}}} - \frac{1}{2}} \right) \end{align}
where
 $a,k \gt 0$
.
Considering different cases, it can be observed that when
 ${x_3} \gt 0$
,
 $\frac{1}{{1 + {e^{k{x_3}}}}} - \frac{1}{2} \lt 0$
, hence
 ${\dot V_2} \lt 0$
. Similarly, when
 ${x_3} \lt 0$
,
 $\frac{1}{{1 + {e^{k{x_3}}}}} - \frac{1}{2} \gt 0$
, again
 ${\dot V_2} \lt 0$
. Moreover, if and only if when
 ${x_3} = 0$
,
 ${\dot V_2} = 0$
. Therefore,
 ${\dot V_2}$
is negative definite, indicating that the system is uniformly asymptotically stable.
On the sliding surface, it also holds that
 $\dot s = 0$
. Based on Equation (22), it can be further derived that
 \begin{align} {\dot x_5} & = - \frac{{ak{e^{k{x_3}}}}}{{{{(1 + {e^{k{x_3}}})}^2}}}{x_5} \nonumber\\&= - ak\frac{{{e^a}\left( {1 + k\left( {{x_3} - a} \right)} \right) + O\left( {x_3^2} \right)}}{{{{(1 + {e^{ka}}\left( {1 + k\left( {{x_3} - a} \right)} \right))}^2} + O\left( {x_3^2} \right)}} \end{align}
At the equilibrium point, it can be further simplify to:
 \begin{align} {\dot x_5} & = - ak\frac{{1 + k{x_3} + O\left( {x_3^2} \right)}}{{{{(2 + k{x_3})}^2} + O\left( {x_3^2} \right)}}{x_5} \nonumber\\& \approx - ak\frac{{1 + k{x_3} + O\left( {x_3^2} \right)}}{{4 + 4k{x_3} + O\left( {x_3^2} \right)}}{x_5}\nonumber\\& \approx - \frac{{ak}}{4}{x_5} \end{align}
Integrating both sides of the equation, it can be obtained that:
 \begin{align} \mathop \int \limits_{x_5^0}^{x_5^f} \frac{1}{{{x_5}}}d{x_5} = \mathop \int \limits_0^T - \frac{{ak}}{4}dt \end{align}
By solving the differential align, near the equilibrium point, the system state can be represented as:
 \begin{align} x_{5}^{\,f} = x_5^0{e^{ - \frac{{ak}}{4}T}} \end{align}
Therefore, the system exhibits exponential convergence from the sliding surface to the equilibrium state. This completes the proof.
Likewise, for the LOS azimuthal orientation, the sliding surface is configured as
 \begin{align} s = {x_6} - \left( {a/\left( {1 + {e^{k{x_4}}}} \right) - 0.5a} \right). \end{align}
Therefore, the command in the azimuthal direction is
 \begin{align} a_{Mz}^i = {x_1}{\mathrm{cos}}{q_{\varepsilon, i}}\left[ {\frac{{2{x_2}{x_6}}}{{x1}} - 2{x_5}{x_6}{\mathrm{tan}}{q_{\varepsilon, i}} - {k_1}s - {k_2}{\mathrm{sign}}{{(s)}^\rho } - \frac{{ak{e^{k{x_4}}}{x_6}}}{{{{(1 + {e^{k{x_4}}})}^2}}}} \right] + \tilde d_z^i \end{align}
where
 $\tilde d_z^i = \left( {{a_{Tz}} + d_z^i} \right){x_1}{\mathrm{cos}}{q_{\varepsilon, i}}$
is the disturbance caused by the target manoeuver and unmodeled dynamics.
Using the proposed sliding mode guidance law ensures that the system converges to the sliding surface in finite time, and the convergence from the sliding surface to the equilibrium state is exponential. The proof follows similar reasoning as presented above.
After obtaining the guidance commands in LOS frame system from Equations (13), (23) and (33), inner loop commands in the ballistic frame system can be derived through the frame transformations, including thrust
 $P$
, lift
 $L$
, drag
 $D$
and lateral force
 $Z$
. More details can be found in Ref. (Reference Wang, Liu, Wang and Tang39). Further, attitude commands can be computed, such as angle-of-attack and sideslip, and angle tracking is achieved through the inner-loop attitude controller [Reference Tao, Lin, Song and Li40].
Remark 3. Considering that the focus of this paper is on the design of RCGL, and the integrated guidance and control simulation is another popular research area, we assume, for simplicity, that the inner loop is ideal and can track the commands in real-time.
The overall flowchart of the simulation is shown as Fig. 3.
Flowchart of inner and outer loop integrated simulation.

3.3 Design of ESO
In order to estimate and compensate for disturbances generated by target manoeuvers and unmodeled dynamics, an ESO is applied for LOS direction and LOS normal direction, respectively.
Regarding the disturbance
 $\tilde d_x^i$
in the LOS direction, the ESO is designed as follows:
 \begin{align} \left( {\begin{array}{*{20}{l}}{{{\dot z}_{x1}} = {z_{x2}} - {\beta _{x1}}\left( {{t_{f,i}} - {z_{x1}}} \right) + {{\tilde u}_{x,i}}}\\[3pt] {{{\dot z}_{x2}} = {\beta _2}\left( {{t_{f,i}} - {z_{x1}}} \right)}\end{array}} \right.\end{align}
where
 ${\beta _{x1}} = 2{w_{xo}},{\beta _{x2}} = w_{xo}^2$
, and
 ${w_{xo}}$
is the bandwidth of the observer. According to the proof by Gao et al. [Reference Gao38], appropriate parameter design can achieve accurate estimation of disturbances, that is,
 ${z_{x1}} \to {t_{f,i}}$
and
 ${z_{x2}} \to \tilde d_x^i$
.
Similarly, in order to compensate for target manoeuvers and other disturbances, In the elevation direction of LOS, the ESO is designed as:
 \begin{align} \left( {\begin{array}{l}{{{\dot z}_{y1}} = {z_{y2}} + {\beta _{y1}}\left( {{x_3} - {z_{y1}}} \right)}\\[3pt] {{{\dot z}_{y2}} = {z_{y3}} + {\beta _{y2}}\left( {{x_3} - {z_{y1}}} \right) + \left( { - a_{My}^i - 2{x_2}{x_5} - {x_1}x_6^2{\mathrm{sin}}{q_{\varepsilon, i}}{\mathrm{cos}}{q_{\varepsilon, i}}} \right)/{x_1}}\\[3pt] {{{\dot z}_{y3}} = {\beta _{y3}}\left( {{x_3} - {z_{y1}}} \right)}\end{array}} \right..\end{align}
In the azimuth direction of LOS, the observer is designed as follows,
 \begin{align}\left( {\begin{array}{l}{{{\dot z}_{z1}} = {z_{z2}} + {\beta _{z1}}\left( {{x_4} - {z_{z1}}} \right)}\\[3pt] {{{\dot z}_{z2}} = {z_{z3}} + {\beta _{z2}}\left( {{x_4} - {z_{z1}}} \right) + 2{x_5}{x_6}{\mathrm{tan}}{q_{\varepsilon, i}} + a_{Mz}^i/\left( {{x_1}{\mathrm{cos}}{q_{\varepsilon, i}}} \right) - 2{x_2}{x_6}/{x_1}}\\[3pt] {{{\dot z}_{z3}} = {\beta _{z3}}\left( {{x_4} - {z_{z1}}} \right)}\end{array}} \right. \end{align}
where
 ${\beta _{y1}} = 3{w_{yo}},{\beta _{y2}} = 3w_{yo}^2,{\beta _{y3}} = 3w_{yo}^3$
,
 ${\beta _{z1}} = 3{w_{zo}},{\beta _{z2}} = 3w_{zo}^2,{\beta _{z3}} = 3w_{zo}^3$
, and
 ${w_{yo}}$
,
 ${w_{zo}}$
are the bandwidth of the observer, respectively. By setting the parameters reasonably, it can be achieved that
 ${z_{y3}} \to \tilde d_y^i$
and
 ${z_{z3}} \to \tilde d_z^i$
.
4.0 Numerical simulation and HIL experiment
This section demonstrates the effectiveness of the proposed algorithm through both simulation and HIL experiments. Initially, under ideal conditions, the verification process establishes that missiles launched from different locations can simultaneously strike the target while adhering to attack angle constraints and facing severe actuator saturation. Next, the discussion focuses on the role of guidance law hyperparameters and the performance of the guidance law under thruster failure. The advantages of the proposed nonlinear RCGL are further illustrated through comparisons with other advanced algorithms.
4.1 Initial conditions
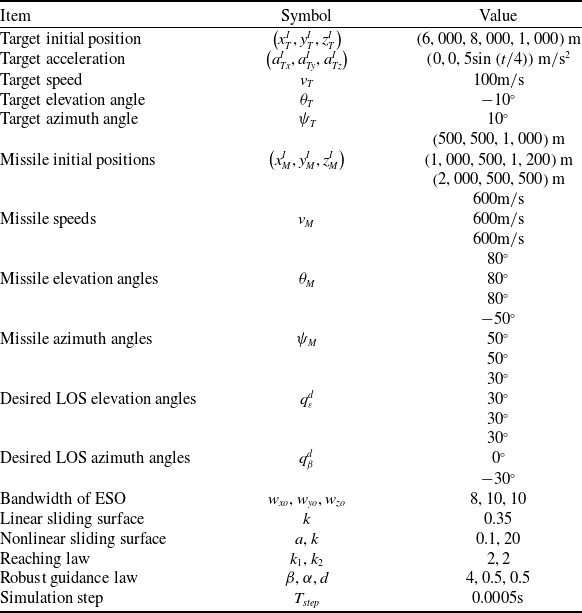
In the simulation, the parameters of the scenario and the hyperparameters of the guidance law are shown in Table 1. When utilising the proposed nonlinear surface, the maximum available overload in the X-Y-Z direction under the LOS frame is set to
 $\left( { \pm 1.5g, \pm 10g, \pm 10g} \right)$
, respectively. However, in the case of adopting the linear sliding surface, the overload is adjusted to
 $\left( { \pm 1.5g, \pm 30g, \pm 30g} \right)$
, respectively. This adjustment ensures the efficacy of the method using the linear sliding surface. Here,
 $g$
represents the acceleration due to gravity.
Simulation initial parameters

4.2 Numerical simulation
In this subsection, simulations are conducted separately for both ideal and failure conditions.
Case 1: Ideal condition
In this scenario, three missiles are simultaneously launched from different positions to engage a moving target, satisfying terminal time and angle constraints. The simulation results are illustrated in Fig. 4. As shown in Fig. 4(b), the remaining flight time converges within
 $1.5$
seconds and remains constant until the end of the strike. Consequently, the acceleration in the X-axis direction, displayed in Fig. 4(e), maintains a zero value after the remaining flight time convergence.
Spatiotemporal cooperative guidance under ideal conditions.

Remark 4. To contrast and illustrate the advantages of the proposed nonlinear sliding mode guidance law in handling actuator saturation constraints, a coefficient
 $k = 0.35$
is selected for the linear sliding mode surface. This choice ensures that the convergence time of both guidance laws is comparable. This design will also assess the magnitude of required accelerations.
As depicted in Fig. 4(c) and (d), while ensuring the same final convergence time, the linear SMC necessitates larger guidance commands in the early stages, as shown in Fig. 4(e), resulting in a faster initial convergence rate. However, as the guidance error reduces in the later stages, the convergence rate significantly slows down. In contrast, the proposed nonlinear SMC requires guidance commands that are only one-third of those needed by the linear guidance law. The system converges at a relatively stable rate, resulting in a smoother flight trajectory, as illustrated in Fig. 4(a). Furthermore, Fig. 4(f) demonstrates that, with the same convergence time, the proposed nonlinear guidance law can handle more stringent input saturation constraints and achieve smaller terminal guidance errors.
Figure 5 compares simulation outcomes corresponding to various sliding mode surfaces. Figure 6 depicts these surfaces. The findings demonstrate that adjusting the hyperparameters of the nonlinear sliding surface appropriately enables striking a balance between input saturation constraints and convergence speed.
The influence of hyperparameters on guidance results.

Comparison of sliding surface.

Case 2: Thruster failure condition
In this scenario, assume that at simulation time
 $t = 5{\mathrm{s}}$
, Missile 1 experiences a thruster failure. That is,
 $t_{fal}^1 = 5,k_{fal}^1 = 0,{\mathrm{\Delta }}_p^1 = 0$
. According to the law of conservation of energy, although Missile 1 has lost all of its propulsion, the kinetic energy acquired earlier is sufficient to support it in striking the target. Figure 7 illustrates the simulation results using both the proposed RCGL and the fully distributed cooperative guidance law (DCGL). The inclusion of the faulty Missile 1 in cooperative decision-making notably degrades the overall guidance performance of the cooperative system, as evident from Fig. 7(d). When employing the proposed leader-follower hybrid cooperative guidance law, Missiles 2 and 3 track Missile 1 along the line of sight. However, with the fully DCGL, the coordination of time-to-go persists, ultimately leading to compromised angle maintenance.
Spatiotemporal cooperative guidance under thruster failure condition.

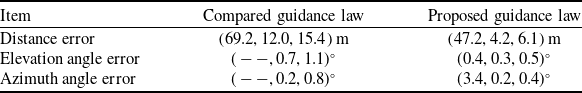
Table 2 displays the terminal guidance outcomes under the thruster failure condition. Entries marked with
 $ - - {\mathrm{\;}}$
indicate state divergence. The results illustrate that the proposed robust cooperative guidance law successfully manages thruster complete failure, ensuring dependable cooperative attack capabilities.
Terminal errors under thruster failure

4.3 HIL experiment
The HIL experiment serves as a valuable tool to identify potential issues prior to actual flight tests. It allows for evaluating the validity of model assumptions and considering factors that may be overlooked in real-world scenarios. Furthermore, the HIL experiment facilitates real-time assessment of the performance and robustness of guidance and control algorithms. This proactive approach not only minimises the dependency on flight tests but also mitigates associated risks, providing opportunities to optimise system performance. Figure 8 illustrates the HIL system architecture, while Fig. 9 details the experimental equipment used.
HIL system architecture.

HIL experimental equipment.

Remark 5. This paper primarily investigates the cooperative guidance algorithm for multiple missiles. Due to experimental constraints, a virtual ad hoc network is employed to simulate the communication links.
The results of the HIL experiment are depicted in Fig. 10. They indicate that the proposed robust cooperative guidance law effectively mitigates signal transmission delays and unmodeled disturbances, demonstrating robust real-time performance. These findings validate the effectiveness of the proposed guidance law on the hardware platform, thereby supporting its practical application.
Spatiotemporal coordination of HIL experiments.

5.0 Conclusion
Based on a distributed consensus protocol and a nonlinear sliding mode guidance law, this paper proposes a three-dimensional robust cooperative guidance law that incorporates time and attack angle constraints. The design of the nonlinear sliding surface enables the algorithm to manage strict input saturation constraints while maintaining convergence speed. An extended state observer is employed to estimate and compensate for disturbances arising from target manoeuvers and unmodeled dynamics. The robust nonlinear cooperative guidance law ensures that the entire system can achieve reliable cooperation within finite time, even in the event of thruster failure in individual missiles. The finite-time and exponential convergence properties of the algorithm are established using Lyapunov theory. Experimental results affirm that the algorithm effectively handles stringent input saturation constraints and thruster failures. HIL experiments demonstrate the algorithm’s strong disturbance rejection capability and real-time performance, underscoring its practical applicability. In the future, if multiple aircraft experience failures within a cooperative system, further research is needed to determine how to select a virtual leader to balance the constraints imposed by each faulty aircraft.
Acknowledgements
This work was supported by the Key Laboratory of Spacecraft Design Optimization and Dynamic Simulation Technologies, National Natural Science Foundation of China No.62073020, Joint Funds of the National Natural Science Foundation of China No.U24B20177, and Beijing Links Tech.
Data availability statement
The data used to support the findings of this study are included within the article.
Competing interests
The authors declared that they have no conflicts of interest to this work.