



No CrossRef data available.
Article contents
How to state necessary optimality conditions for control problems with deviating arguments?
Published online by Cambridge University Press: 20 March 2008
Abstract
The aim of this paper is to give a general idea to state optimality conditions of control problems in the following form: ${\displaystyle\inf_{{\displaystyle(u,v)\in {\cal U}_{ad}}}\int_{0}^{1} f\left(t, u(\theta_v(t)),u^{\prime}(t),v(t)\right){\rm d}t}$ 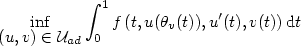 , (1)where ${\cal U}_{ad} $
 is a set of admissible controls and $\theta_v$
 is the solution of the following equation: $\{ \frac{{\rm d}\theta(t)}{{\rm d}t}=g(t,\theta(t),v(t)), t\in [0,1]$
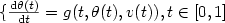 ; $\displaystyle\theta(0)=\theta_0, \theta(t)\in [0,1]\forall t$
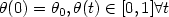 . (2).The results are nonlocal and new.
Information
- Type
- Research Article
- Information
- ESAIM: Control, Optimisation and Calculus of Variations , Volume 14 , Issue 2 , April 2008 , pp. 381 - 409
- Copyright
- © EDP Sciences, SMAI, 2008
References
G. Carlier and R. Tahraoui, On some optimal control problems governed by a state equation with memory. ESAIM: COCV (to appear)
Drakhlin, M., On the variational problem in the space of absolutely continuous functions.
Nonlin. Anal. TMA
23 (1994) 1345–1351.
CrossRef
Drakhlin, M. and Litsyn, E., On the variation problem for a family of functionals in the space of absolutly continuous functions.
Nonlin. Anal. TMA
26 (1996) 463–468.
CrossRef
Drakhlin, M.E. and Stepanov, E., On weak lower semi-continuity for a class of functionals with deviating argument.
Nonlin. Anal. TMA
28 (1997) 2005–2015.
CrossRef
Drakhlin, M.E., Litsyn, E. and Stepanov, E., Variational methods for a class of nonlocal functionals.
Comput. Math. Appl
37 (1999) 79–100.
CrossRef
L.C. Evans and R.F. Gariepy, Measure theory and fine properties of functions. CRC Press, Inc. (1992).
L. Freddi, Limits of control problems with weakly converging nonlocal input operators. Calculus of variations and optimal control (Haifa, 1998), Math. 411, Chapman Hall/CRC, Boca Raton, FL (2000) 117–140.
Gruzdev, A.A. and Gusarenko, S.A., On reduction of variational problems to extremal problems without constraints.
Russians mathematics
38 (1994) 37–47.
Jouini, E., Koehl, P.F. and Touzi, N., Optimal investment with taxes: an optimal control problem with endogeneous delay.
Nonlin. Anal. TMA
37 (1999) 31–56.
CrossRef
Jouini, E., Koehl, P.F. and N.Touzi, Optimal investment with taxes: an existence result.
J. Math. Economics
33 (2000) 373–388.
CrossRef
Kamenskii, G.A., Variational and boundary value problems with deviating argument.
Diff. Equ
6 (1970) 1349–1358.
Kamenskii, G.A., On some necessary conditions of functionals with deviating argument.
Nonlin. Anal. TMA
17 (1991) 457–464.
CrossRef
Kamenskii, G.A., Boundary value problems for differential-difference equations arising from variational problems.
Nonlin. Anal. TMA
18 (1992) 801–813.
CrossRef
P.L. Lions and B. Larrouturou, Optimisation et commande optimale, méthodes mathématiques pour l'ingénieur, cours de l'École Polytechnique, Palaiseau, France.
L. Samassi, Calculus of variation for funtionals with deviating arguments. Ph.D. thesis, University Paris-Dauphine, France (2004).
Samassi, L. and Tahraoui, R., Comment établir des conditions nécessaires d'optimalité dans les problèmes de contrôle dont certains arguments sont déviés ?
C.R. Acad. Sci. Paris Ser
338 (2004) 611–616.
CrossRef
Wheeler, J.A. and Feynman, R.P., Classical electrodynamics in term of direct interparticle actions.
Rev. Modern Phys
21 (1949) 425–433.
CrossRef
- 4
- Cited by