



1 Introduction
The flow of a homogeneous fluid over an obstacle is a fundamental problem in fluid mechanics and has been heavily studied from many points of view. A widely used approach for shallow fluids is the application of hydraulic concepts when the flow can be classified in terms of the upstream Froude number
 $F=U/c$
, where
 $U$
is the uniform upstream flow and
 $c=(gh)^{1/2}$
is the linear long-wave speed in water with an undisturbed depth
 $h$
. The flow is then supercritical, subcritical or transcritical depending on whether
 $F>1$
,
 $F<1$
or
 $F\approx 1$
, see for instance the monograph by Baines (Reference Baines1995). In the supercritical case waves generated by the flow interaction with the obstacle propagate downstream away from the obstacle and the flow at the obstacle location is a locally steady elevation. In the subcritical case, waves propagate upstream and downstream away from the obstacle, and the flow at the obstacle location is a locally steady depression accompanied by steady lee waves downstream of the obstacle. Both these cases can be well understood qualitatively using linearised theory.
However, linearized theory fails in the transcritical regime, and then nonlinear shallow water theory leads to the determination of a locally steady hydraulic flow over the obstacle, with an upstream elevation and a downstream depression, each terminated by upstream- and downstream-propagating shocks. In the presence of wave dispersion, these shocks are resolved by undular bores. In the weakly nonlinear long-wave regime the forced Korteweg–de Vries (KdV) equation has been invoked to describe this flow, see Akylas (Reference Akylas1984), Cole (Reference Cole1985), Grimshaw & Smyth (Reference Grimshaw and Smyth1986), Lee et al. (Reference Lee, Yates and Wu1989), Binder, Vanden-Broeck & Dias (Reference Binder, Vanden-Broeck and Dias2005), Binder, Dias & Vanden-Broeck (Reference Binder, Dias and Vanden-Broeck2006), Grimshaw et al. (Reference Grimshaw, Zhang and Chow2007) and the recent review by Grimshaw (Reference Grimshaw2010). Various aspects of the extension to finite amplitudes in the long-wave regime can be found in El et al. (Reference El, Grimshaw and Smyth2006, Reference El, Grimshaw and Smyth2008) and El et al. (Reference El, Grimshaw and Smyth2009).
Although transcritical shallow water flow is now quite well understood for a single localised obstacle, there have been comparatively very few studies of the analogous case when the there are two widely separated localised obstacles. This motivated us to examine this case in our recent work, Grimshaw & Maleewong (Reference Grimshaw and Maleewong2015), where in the context of the nonlinear shallow water equations, we showed that the flow evolved in two stages. The first stage is the generation of an upstream elevation shock and a downstream depression shock at each obstacle alone, isolated from the other obstacle. The second stage is the interaction of these two shocks between the two obstacles, followed by an adjustment to a hydraulic flow over both obstacles, with criticality being controlled by the higher of the two obstacles and by the second obstacle when they have equal heights. This hydraulic flow is terminated by an elevation shock propagating upstream of the first obstacle and a depression shock propagating downstream of the second obstacle. That study, although fully nonlinear, was in the context of the nonlinear shallow water equations which contain no wave dispersion.
The primary purpose of this present paper is to remedy that, and so here we examine the flow over two localized obstacles in the context of the forced KdV equation, which contains a balance between weak nonlinearity, weak dispersion and small-amplitude forcing. The essential new feature is then that the generated shocks are replaced by undular bores, that is nonlinear wavetrains, and then the main question is how the undular bores, generated between the obstacles, interact. Earlier, Pratt (Reference Pratt1984) used a combination of steady hydraulic theory, numerical simulations of the nonlinear shallow water equations and laboratory experiments to infer that the formation of dispersive waves between the obstacles is needed to obtain a stable solution. More recently Dias & Vanden-Broeck (Reference Dias and Vanden-Broeck2004), Binder et al. (Reference Binder, Vanden-Broeck and Dias2005), Ee & Clarke (Reference Ee and Clarke2007), Ee et al. (Reference Ee, Grimshaw, Zhang and Chow2010, Reference Ee, Grimshaw, Chow and Zhang2011) have examined the possible presence of such waves for steady flows, while Donahue & Shen (Reference Donahue and Shen2010) and Chardard et al. (Reference Chardard, Dias, Nguyen and Vanden-Broeck2011) considered the stability of these flows and Grimshaw et al. (Reference Grimshaw, Zhang and Chow2009) considered the related problem of unsteady flow over a wide hole. Our emphasis is on the transcritical regime for two widely spaced localised obstacles. The forced KdV equation is described in § 2 and numerical solutions presented in § 3. We conclude in § 4.
2 Forced Korteweg–de Vries equation
The forced KdV equation has been derived for water waves by Akylas (Reference Akylas1984), Cole (Reference Cole1985) and Lee et al. (Reference Lee, Yates and Wu1989) and for internal waves by Grimshaw & Smyth (Reference Grimshaw and Smyth1986), see also the recent review by Grimshaw (Reference Grimshaw2010). It is technically valid in the transcritical regime when
 $F\approx 1$
, and in non-dimensional units based on a length scale
 $h$
and a time scale
 $(h/g)^{1/2}$
, it is given by
 $$\begin{eqnarray}-\unicode[STIX]{x1D701}_{t}-\unicode[STIX]{x1D6E5}\unicode[STIX]{x1D701}_{x}+\frac{3}{2}\unicode[STIX]{x1D701}\unicode[STIX]{x1D701}_{x}+\frac{1}{6}\unicode[STIX]{x1D701}_{xxx}+\frac{f_{x}}{2}=0,\quad \unicode[STIX]{x1D6E5}=F-1.\end{eqnarray}$$
Here
 $\unicode[STIX]{x1D701}$
is the free-surface displacement above the undisturbed surface. The initial condition is
 $$\begin{eqnarray}\unicode[STIX]{x1D701}=0,\quad \text{at }t=0.\end{eqnarray}$$
It is based on the usual KdV balance where
 $\unicode[STIX]{x1D701}\sim \unicode[STIX]{x1D6FC}^{2}$
,
 $\unicode[STIX]{x2202}/\unicode[STIX]{x2202}x\sim \unicode[STIX]{x1D6FC}$
,
 $\unicode[STIX]{x2202}/\unicode[STIX]{x2202}t\sim \unicode[STIX]{x1D6FC}^{3}$
,
 $\unicode[STIX]{x1D6E5}\sim \unicode[STIX]{x1D6FC}^{2}$
and
 $f\sim \unicode[STIX]{x1D6FC}^{4}$
where
 $\unicode[STIX]{x1D6FC}\ll 1$
is the governing small parameter.
For a single localized obstacle, that is,
 $f(x)$
has a maximum height
 $\unicode[STIX]{x1D716}_{m}>0$
at
 $x=0$
say, and has effectively compact support such as a Gaussian, the transcritical problem can be solved asymptotically in two parts, see Grimshaw & Smyth (Reference Grimshaw and Smyth1986) and the review by Grimshaw (Reference Grimshaw2010). In the first part, the linear dispersive term
 $\unicode[STIX]{x1D701}_{xxx}$
is omitted, and the resulting forced Hopf equation can be exactly solved using characteristics,
 $$\begin{eqnarray}\frac{\text{d}x}{\text{d}t}=\unicode[STIX]{x1D6E5}-\frac{3\unicode[STIX]{x1D701}}{2},\quad \frac{\text{d}\unicode[STIX]{x1D701}}{\text{d}t}=\frac{f_{x}}{2}.\end{eqnarray}$$
With the initial condition (2.2), this can be readily integrated explicitly. When characteristics intersect, a shock forms and must satisfy the shock condition
 $$\begin{eqnarray}(S-\unicode[STIX]{x1D6E5})[\unicode[STIX]{x1D701}]+{\textstyle \frac{3}{4}}[\unicode[STIX]{x1D701}^{2}]=0,\end{eqnarray}$$
where
 $[\cdot ]$
is the jump across the shock and
 $S$
is the shock speed. Our main interest is in the transcritical regime defined here by
 $$\begin{eqnarray}2\unicode[STIX]{x1D6E5}^{2}<3\unicode[STIX]{x1D716}_{m},\end{eqnarray}$$
when such shocks form upstream and downstream of the obstacle. Omitting details, the outcome is that a localised steady solution, sometimes called the hydraulic solution, forms over the obstacle, given by
 $$\begin{eqnarray}\displaystyle & \displaystyle 4\unicode[STIX]{x1D6E5}^{2}-12\unicode[STIX]{x1D6E5}\unicode[STIX]{x1D701}+9\unicode[STIX]{x1D701}^{2}=\text{constant}-6f(x), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \text{and so}~3\unicode[STIX]{x1D701}=2\unicode[STIX]{x1D6E5}\mp \text{sign}[x]\{6[\unicode[STIX]{x1D716}_{m}-f(x)]\}^{1/2}. & \displaystyle\end{eqnarray}$$
Here equation (2.6) can readily by direct integration of the Hopf equation obtained from the steady version of (2.1) after omitting the linear dispersive term. The constant of integration is determined by the hydraulic condition that
 $\unicode[STIX]{x1D701}_{x}\neq 0$
at the top of the obstacle, where then
 $\unicode[STIX]{x1D701}=2\unicode[STIX]{x1D6E5}/3$
and the constant takes the value
 $6\unicode[STIX]{x1D716}_{m}$
. This is terminated by upstream and downstream shocks with magnitude
 $\unicode[STIX]{x1D701}_{\mp }$
,
 $$\begin{eqnarray}3\unicode[STIX]{x1D701}_{\mp }=2\unicode[STIX]{x1D6E5}\pm \{6\unicode[STIX]{x1D716}_{m}\}^{1/2}.\end{eqnarray}$$
Note that
 $\unicode[STIX]{x1D701}_{+}<0,\unicode[STIX]{x1D701}_{-}>0$
so that the upstream shock is an elevation and the downstream shock is a depression. The speeds of these shocks are found from (2.4), that is
 $$\begin{eqnarray}4S_{\mp }=3\unicode[STIX]{x1D701}_{\mp }=2\unicode[STIX]{x1D6E5}\mp \{6\unicode[STIX]{x1D716}_{m}\}^{1/2},\end{eqnarray}$$
and
 $S_{-}<0,S_{+}>0$
. Outside the transcritical regime, when
 $\unicode[STIX]{x1D6E5}>(3\unicode[STIX]{x1D716}_{m}/2)^{1/2}$
the flow is supercritical and all characteristics propagate downstream, leaving a steady elevation over the obstacle, while when
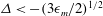 $\unicode[STIX]{x1D6E5}<-(3\unicode[STIX]{x1D716}_{m}/2)^{1/2}$
the flow is subcritical and all characteristics propagate upstream leaving a steady depression over the obstacle. In this subcritical case, when dispersion is restored, stationary lee waves will form behind the obstacle.
In the second part, the shocks are replaced by undular bores using the Gurevich–Pitaeveskii adaptation, see Gurevich & Pitaevskii (Reference Gurevich and Pitaevskii1974), of the Whitham modulation theory (Whitham Reference Whitham1965, Reference Whitham1974; Fornberg & Whitham Reference Fornberg and Whitham1978). A brief summary of that theory is reproduced here in the appendix, adapted from Grimshaw (Reference Grimshaw2010). The undular bore in
 $x<0$
is described by (A 3)–(A 6) with
 $\unicode[STIX]{x1D701}_{0}=\unicode[STIX]{x1D701}_{-}$
. Hence it occupies the zone
 $$\begin{eqnarray}\unicode[STIX]{x1D6E5}-\unicode[STIX]{x1D701}_{-}<\frac{x}{t}<\max \left\{0,~\unicode[STIX]{x1D6E5}+\frac{3\unicode[STIX]{x1D701}_{-}}{2}\right\}.\end{eqnarray}$$
Note that this upstream wavetrain is constrained to lie in
 $x<0$
, and hence is only fully realised if
 $\unicode[STIX]{x1D6E5}<-3\unicode[STIX]{x1D701}_{-}/2$
. Combining this criterion with (2.5) and (2.8) defines the regime
 $$\begin{eqnarray}-\left(\frac{3\unicode[STIX]{x1D716}_{m}}{2}\right)^{1/2}<\unicode[STIX]{x1D6E5}<-\frac{1}{2}\left(\frac{3\unicode[STIX]{x1D716}_{m}}{2}\right)^{1/2},\end{eqnarray}$$
where a fully developed undular bore solution can develop upstream. On the other hand, the regime
 $\unicode[STIX]{x1D6E5}>-3\unicode[STIX]{x1D701}_{-}/2$
or
 $$\begin{eqnarray}-\frac{1}{2}\left(\frac{3\unicode[STIX]{x1D716}_{m}}{2}\right)^{1/2}<\unicode[STIX]{x1D6E5}<\left(\frac{3\unicode[STIX]{x1D716}_{m}}{2}\right)^{1/2},\end{eqnarray}$$
is where the upstream undular bore is only partially formed and is attached to the obstacle. In this case, the modulus
 $m$
of the Jacobi elliptic function varies from
 $1$
at the leading edge (thus describing solitary waves of amplitude
 $2\unicode[STIX]{x1D701}_{-}$
) to a value
 $m_{-}$
 $({<}1)$
at the obstacle, where
 $m_{-}$
can be found by putting
 $x=0$
in (A 5).
The undular bore in
 $x>0$
can also be described by (A 3) to (A 6) with
 $\unicode[STIX]{x1D701}_{0}=-A_{+}$
, after using the transformation (A 8). Hence it occupies the zone
 $$\begin{eqnarray}\max \left\{0,~\unicode[STIX]{x1D6E5}-\frac{\unicode[STIX]{x1D701}_{+}}{2}\right\}<\frac{x}{t}<\unicode[STIX]{x1D6E5}-3\unicode[STIX]{x1D701}_{+}.\end{eqnarray}$$
Here, this downstream wavetrain is constrained to lie in
 $x>0$
, and hence is only fully realised if
 $\unicode[STIX]{x1D6E5}>\unicode[STIX]{x1D701}_{+}/2$
, and then the leading solitary wave has an amplitude
 $-2\unicode[STIX]{x1D701}_{+}$
. Combining this criterion with (2.5) and (2.8) defines the regime (2.12), and so a fully detached downstream undular bore coincides with the case when the upstream undular bore is attached to the obstacle. On the other hand, in the regime (2.11), when the upstream undular bore is detached from the obstacle, the downstream undular bore is attached to the obstacle, with a modulus
 $m_{+}({<}1)$
at the obstacle, where
 $m_{+}$
can again be found from the counterpart of (A 5) evaluated at
 $x=0$
.
When there are two widely placed obstacles with maximum heights
 $\unicode[STIX]{x1D716}_{1,2}$
respectively, there are several regimes to consider depending on
 $\unicode[STIX]{x1D6E5}$
and
 $\unicode[STIX]{x1D716}_{1,2}$
. The main regime is when the flow is transcritical at each obstacle separately, that is
 $\unicode[STIX]{x1D6E5}^{2}<\min [\unicode[STIX]{x1D716}_{1},\unicode[STIX]{x1D716}_{2}]$
, and then the solution evolves in three stages. In the first stage, this local steady solution with upstream and downstream undular bores holds for each obstacle separately. But when there are two obstacles, in the second stage the upstream elevation undular bore from the second obstacle will meet the downstream depression undular bore from the first obstacle. These interact and possibly then also modulate the upstream elevation undular bore from the first obstacle and the downstream depression undular bore from the first obstacle. Our main purpose here is to determine the outcome of that interaction. The third stage is when the solution appears to settle outside each obstacle, but with continuing wave interactions between the obstacles.
We note that in this third stage a localised steady solution can be found given again by (2.7) but with
 $\unicode[STIX]{x1D716}$
replaced by
 $\max [\unicode[STIX]{x1D716}_{1,2}]$
. That is, a hydraulic solution controlled by the larger of the two obstacles. This was the outcome found by Grimshaw & Maleewong (Reference Grimshaw and Maleewong2015) in the fully nonlinear non-dispersive case. The smaller of the obstacles is then in either a locally supercritical flow, or a locally subcritical flow, depending on whether it is the second or the first obstacle. This is shown by noting that, relative to a level
 $\unicode[STIX]{x1D701}_{0}$
,
 $\unicode[STIX]{x1D6E5}$
in (2.1) is replaced by
 $\unicode[STIX]{x1D6E5}^{\prime }=\unicode[STIX]{x1D6E5}-3\unicode[STIX]{x1D701}_{0}/2$
. Thus if
 $\unicode[STIX]{x1D716}_{1}>\unicode[STIX]{x1D716}_{2}$
, put
 $\unicode[STIX]{x1D701}_{0}=\unicode[STIX]{x1D701}_{+}$
and then
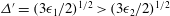 $\unicode[STIX]{x1D6E5}^{\prime }=(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}>(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}$
and so the flow is supercritical at the second obstacle. Alternatively if
 $\unicode[STIX]{x1D716}_{2}>\unicode[STIX]{x1D716}_{1}$
, put
 $\unicode[STIX]{x1D701}_{0}=\unicode[STIX]{x1D701}_{-}$
and then
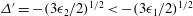 $\unicode[STIX]{x1D6E5}^{\prime }=-(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}<-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}$
and so the flow is subcritical at the first obstacle. When the obstacles have equal heights,
 $\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}$
, Grimshaw & Maleewong (Reference Grimshaw and Maleewong2015) found that this local hydraulic solution could be found with critical control exerted at the second obstacle and a contact discontinuity at the first obstacle. However that conclusion was based on higher-order nonlinear effects beyond the regime of the forced Korteweg–de Vries (fKdV) equation (2.1), and so cannot be assumed to hold here. Instead we find that in this case of obstacles of equal heights, either obstacle can exert critical control depending on the value of
 $\unicode[STIX]{x1D6E5}$
. The numerical simulations reported in § 3 suggest that when
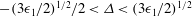 $-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}/2<\unicode[STIX]{x1D6E5}<(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}$
so that the upstream undular bore is attached to each obstacle while the downstream undular bore is detached. In this case it is the first obstacle which exerts control, since then the downstream undular bore will eventually pass over the second obstacle leaving a supercritical flow there, although there may still be continuing wave activity between the obstacles. On the other hand when
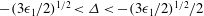 $-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}<\unicode[STIX]{x1D6E5}<-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}/2$
so that the downstream undular bore is attached to each obstacle, while the upstream undular bore is detached, then it is the second obstacle which exerts control since then the upstream undular bore will eventually pass over the first obstacle leaving a subcritical flow there, although again there may still be continuing wave activity between the obstacles.
3 Numerical simulations
3.1 Pseudospectral method
The fKdV in (2.1) with initial condition (2.2) is solved numerically by the pseudospectral method. The computational domain is
 $-L<x<L$
, with
 $L=8192$
. The forcing
 $f(x)$
is composed of two obstacles given by
 $$\begin{eqnarray}f(x)=\unicode[STIX]{x1D716}_{1}\exp (-(x-x_{a})^{2}/w)+\unicode[STIX]{x1D716}_{2}\exp (-(x-x_{b})^{2}/w),\end{eqnarray}$$
where
 $\unicode[STIX]{x1D716}_{1}$
and
 $\unicode[STIX]{x1D716}_{2}$
are the obstacle heights and
 $x_{a}$
and
 $x_{b}$
are the obstacle locations, respectively. Here we set
 $x_{a}=-2050$
and
 $x_{b}=-2000$
and set the obstacle width
 $w=50$
. Since the boundary conditions are periodic, we insert a sponge layer in (2.1) by inserting a term,
 $s(x)$
, to absorb small waves approaching the boundaries,
 $$\begin{eqnarray}-\unicode[STIX]{x1D701}_{t}-\unicode[STIX]{x1D6E5}\unicode[STIX]{x1D701}_{x}+\frac{3}{4}(\unicode[STIX]{x1D701}^{2})_{x}+\frac{1}{6}\unicode[STIX]{x1D701}_{xxx}+\frac{f_{x}}{2}-s(x)\unicode[STIX]{x1D701}=0,\end{eqnarray}$$
 $$\begin{eqnarray}s(x)=\frac{\unicode[STIX]{x1D708}}{2}[\{1+\tanh (\unicode[STIX]{x1D705}(x-K/2))\}\{1-\tanh (\unicode[STIX]{x1D705}(x+K/2))\}].\end{eqnarray}$$
Here we set
 $\unicode[STIX]{x1D708}=5$
,
 $\unicode[STIX]{x1D705}=0.002$
and
 $K=7750$
.
The fKdV equation (3.2) is solved numerically using a combination of a finite different method in time and a Fourier pseudospectral method in space. That is, we write (3.2) as
 $$\begin{eqnarray}\unicode[STIX]{x1D701}_{t}=M(\unicode[STIX]{x1D701})=-\unicode[STIX]{x1D6E5}\,\unicode[STIX]{x1D701}_{x}+{\textstyle \frac{3}{4}}(\unicode[STIX]{x1D701}^{2})_{x}+{\textstyle \frac{1}{6}}\,\unicode[STIX]{x1D701}_{xxx}+{\textstyle \frac{1}{2}}\,f_{x}-s(x)\unicode[STIX]{x1D701}.\end{eqnarray}$$
Then we apply the fourth-order Runge–Kutta method,
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}\unicode[STIX]{x1D701}^{n+1}=\unicode[STIX]{x1D701}^{n}+\frac{1}{6}\{M_{1}+2M_{2}+2M_{3}+M_{4}\},\\ M_{1}=M(\unicode[STIX]{x1D701}^{n}),M_{2}=M(\unicode[STIX]{x1D701}^{n}+M_{1}/2),M_{3}=M(\unicode[STIX]{x1D701}^{n}+M_{2}/2),M_{4}=M(\unicode[STIX]{x1D701}^{n}+M_{3}),\end{array}\right\}\end{eqnarray}$$
where the superscript
 $n$
refers to the time step. Then the spatial terms are evaluated by a pseudospectral method. We introduce the approximate solution
 $$\begin{eqnarray}\unicode[STIX]{x1D701}(x,t)=\mathop{\sum }_{k=-N}^{N}a_{k}(t)\exp (\text{i}kx),\end{eqnarray}$$
where
 $a_{k}(t)$
are the coefficients to be determined; note that
 $a_{-k}=\bar{a_{k}}$
in order to keep
 $\unicode[STIX]{x1D701}$
real valued. Let
 $\unicode[STIX]{x1D701}_{j}^{n}$
denote the value of
 $\unicode[STIX]{x1D701}$
at grid point
 $x_{j}$
and time
 $t^{n}$
. To find
 $\unicode[STIX]{x1D701}_{j}^{n+1}$
, we summarize the main steps as follows.
-
(i) Given
 $\unicode[STIX]{x1D701}_{j}^{n}=\unicode[STIX]{x1D701}(x_{j},t_{n})$
, we evaluate
$a_{k}^{n}=a_{k}(t_{n})$
from (3.6) using a fast Fourier transform (FFT) algorithm. The derivatives of the linear terms are calculated in the spectral space.
-
(ii) The nonlinear term is found similarly, that is, we get
$\unicode[STIX]{x1D701}(x_{j},t_{n})$
at each grid point
$x_{j}$
, then find
$\unicode[STIX]{x1D701}(x_{j},t_{n})^{2}$
in the physical space. -
(iii) Given
$\unicode[STIX]{x1D6E5}$
, and the shape of obstacles
$f(x)$
, we can calculate
$\unicode[STIX]{x1D701}_{j}^{n+1}$
from (3.4) at
$x=x_{j}$
and
$t=t_{n+1}$
.


3.2 Equal obstacle heights
$(\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.1)$
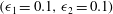
In figure 1, we show the case at exact criticality when
 $F=1,\unicode[STIX]{x1D6E5}=0$
. Here the predicted values of
 $\unicode[STIX]{x1D701}_{\pm }=\mp 0.26$
, see (2.8) and so the leading solitary waves will have predicted amplitudes of
 $0.52$
As indicated above, the flow development takes place in three stages. In the first stage, in a short time period from the start, undular bores are generated from each obstacle moving upstream and downstream, see the time
 $t=60$
. The second stage is the the interaction between the downstream undular bore from the first obstacle and the upstream undular bore from the second obstacle, see the time
 $t=160$
and the region indicated by a double arrow. Note that the amplitude of these waves between the obstacles is approximately twice the value
 $0.52$
of the largest waves from each separate undular bore. At the same time, the upstream undular bore generated from the first obstacle continues moving upstream, and the downstream undular bore generated from the second obstacle continues moving downstream. As time increases, the downstream undular bore generated by the second obstacle moves far away from the obstacle. Then the downstream flow is supercritical at the second obstacle, see the times
 $t=440,1920$
. The simulation is then continued for a very long time to monitor the wave interaction between the two obstacles, see the time
 $t=7600$
. The amplitudes of the interacting waves between the two obstacles are not diminishing. This is referred to as the third stage. In the whole domain, there are upstream, intermediate, and downstream zones, and overall the flow resembles a transcritical flow generated by the first obstacle where there is an attached undular bore upstream, a depressed zone downstream connected with undular bore very far downstream, and locally a supercritical flow over the second obstacle. But, importantly, there is a wave interaction zone between the obstacles, which appears to remain transient without any diminishing amplitude.
Simulations for
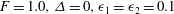 $F=1.0,\unicode[STIX]{x1D6E5}=0,\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}=0.1$
.

In figure 2 we show the case when
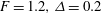 $F=1.2,\unicode[STIX]{x1D6E5}=0.2$
. The transition boundaries
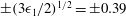 $\pm (3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=\pm 0.39$
, and so this flow is transcritical and in the same regime (2.12) as
 $F=1,\unicode[STIX]{x1D6E5}=0$
. But now
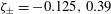 $\unicode[STIX]{x1D701}_{\pm }=-0.125,0.39$
, see (2.8), and so the leading solitary waves will have predicted amplitudes of
 $0.25,0.78$
respectively. Overall the flow develops in a similar manner and the first stage can be seen at
 $t=60,160$
, rather longer than for the case
 $\unicode[STIX]{x1D6E5}=0$
. The second has already begun at
 $t=160$
and is clearly apparent at
 $t=440$
, which is also the beginning of the third stage, seen at the times,
 $t=1920$
, 6580. In this case, the number of waves between the two obstacles is smaller than for the case of
 $F=1.0$
, but the wave amplitudes are similar, and approximately equal to the sum of the largest waves from each separate undular bore, that is
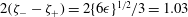 $2(\unicode[STIX]{x1D701}_{-}-\unicode[STIX]{x1D701}_{+})=2\{6\unicode[STIX]{x1D716}\}^{1/2}/3=1.03$
. Also note that the undular bore upstream of the first obstacle is modulated by the large waves between the obstacles, compare the rather uniform structure at
 $t=1920$
with those at
 $t=440,6580$
.
Simulations for
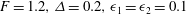 $F=1.2,\unicode[STIX]{x1D6E5}=0.2,\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}=0.1$
.

Simulations for
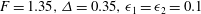 $F=1.35,\unicode[STIX]{x1D6E5}=0.35,\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}=0.1$
.

The case of
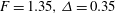 $F=1.35,\unicode[STIX]{x1D6E5}=0.35$
shown in figure 3 is interesting. This value of the Froude number is almost on the boundary of the transition from transcritical flow to fully supercritical flow which occurs at
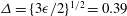 $\unicode[STIX]{x1D6E5}=\{3\unicode[STIX]{x1D716}/2\}^{1/2}=0.39$
. Also now
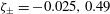 $\unicode[STIX]{x1D701}_{\pm }=-0.025,0.49$
, see (2.8), and so the leading solitary waves will have predicted amplitudes of
 $0.05,0.98$
respectively. The first stage takes longer to develop and at the first obstacle only becomes fully apparent at
 $t=210$
. However, it seems that this stage is suppressed at the second obstacle, presumably because the downstream undular bore from the first obstacle, has already passed over the second obstacle, see
 $t=120,210$
. The second stage is not seen as no waves are discernible between the two obstacles. Instead, the third stage emerges at
 $t=450,5010$
and well-separated solitary waves are emitted from the first obstacle, while there is a local supercritical flow over the second obstacle.
The case of
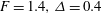 $F=1.4,\unicode[STIX]{x1D6E5}=0.4$
is a supercritical flow and is shown in figure 4. At the very early stage, downstream waves generated by the first obstacle can flow past the localised elevation wave produced by the second obstacle. Then, as transient waves propagate rapidly downstream, a locally steady supercritical flow forms over each obstacle.
Simulations for
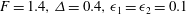 $F=1.4,\unicode[STIX]{x1D6E5}=0.4,\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}=0.1$
.

Next we show the case of
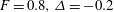 $F=0.8,\unicode[STIX]{x1D6E5}=-0.2$
in figure 5. As before
 $(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=0.39$
, and so this flow is transcritical, but lies in the subcritical regime (2.11) where the upstream undular bore from each obstacle is detached and the downstream undular bore from each obstacle is attached. Now
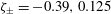 $\unicode[STIX]{x1D701}_{\pm }=-0.39,0.125$
, see (2.8), and so the leading solitary waves will have predicted amplitudes of
 $0.78,0.5$
. This is clearly seen in the first stage at
 $t=60$
. The second stage has begun at
 $t=100$
and is clearly seen at
 $t=520$
. In the third stage, critical control is at the second obstacle, see
 $t=1000,5400$
. There is a strong continuing wave interaction between the obstacles while there is a well-developed undular bore attached to the second obstacle, and a subcritical flow over the first obstacle, where the downstream generated lee waves are interacting with the upstream-propagating undular bore.
Simulations for
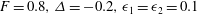 $F=0.8,\unicode[STIX]{x1D6E5}=-0.2,\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}=0.1$
.

Simulations for
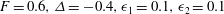 $F=0.6,\unicode[STIX]{x1D6E5}=-0.4,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.1$
.

The case of
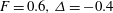 $F=0.6,\unicode[STIX]{x1D6E5}=-0.4$
is a subcritical flow, and shown in figure 6, where
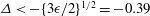 $\unicode[STIX]{x1D6E5}<-\{3\unicode[STIX]{x1D716}/2\}^{1/2}=-0.39$
. However, this flow is very close to this regime boundary, and hence there is some similarity with the case
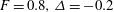 $F=0.8,\unicode[STIX]{x1D6E5}=-0.2$
, although the wave amplitudes are noticeably smaller. From
 $t=40,80,180$
we see the development of an upstream transient and lee wave formation downstream. At
 $t=600,6500$
the waves between the obstacles are irregular and largely suppressed, while a stationary lee wave train has formed downstream of the second obstacle.
The case of
 $F=0.4,\unicode[STIX]{x1D6E5}=-0.6$
is also a subcritical flow, and is shown in figure 7. Compared to the case when
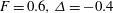 $F=0.6,\unicode[STIX]{x1D6E5}=-0.4$
, the lee waves are greatly suppressed, and at the final stage of
 $t=4600$
, there are two depression waves over each obstacle, with no waves visible between the obstacles.
Simulations for
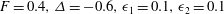 $F=0.4,\unicode[STIX]{x1D6E5}=-0.6,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.1$
.

Simulations for
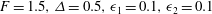 $F=1.5,\unicode[STIX]{x1D6E5}=0.5,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.1$
.

Finally, in this subsection, we note that some exact steady solutions for supercritical flow over two obstacles have been exhibited by Chardard et al. (Reference Chardard, Dias, Nguyen and Vanden-Broeck2011), only some of which are stable. A pertinent example is when each obstacle has a
 $\text{sech}^{2}$
-shape, and then the exact solution is shown in equation (5.3) of their paper. For
 $F=1.5$
and
 $\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}=0.1$
, we calculate from equations (3.10) and (3.11) of their paper, and find that in their terminology,
 $A_{1}=A_{2}=0.0718$
and
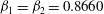 $\unicode[STIX]{x1D6FD}_{1}=\unicode[STIX]{x1D6FD}_{2}=0.8660$
. The comparison of our numerical simulation at time
 $t=138.5$
with their exact solution is shown in figure 8. They are in good agreement and also confirms that this solution is stable. The corresponding transient solutions at various time steps are similar to those in figure 4.
3.3 Unequal obstacle heights
$(\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.2)$
Here we consider the case when
 $\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.2$
so that the second obstacle is larger in amplitude. The case of exact criticality
 $F=1.0,\unicode[STIX]{x1D6E5}=0$
in shown in figure 9. The outcome is similar to the case of equal obstacle heights at exact criticality, shown in figure 1. The flow development takes place in three stages. In the first stage, undular bores are generated from each obstacle moving upstream and downstream, see the time
 $t=80$
. The second stage is the interaction between the downstream undular bore from the first obstacle and the upstream undular bore from the second obstacle, see the time
 $t=180$
and the region indicated by a double arrow. The upstream undular bore generated from the first obstacle continues moving upstream, and the downstream undular bore generated from the second obstacle continues moving downstream. As time increases, the downstream undular bore generated by the second obstacle moves far away from the obstacle. In the third stage, the downstream flow is supercritical at the second obstacle which has the larger height, see the times
 $t=480,6360$
. Upstream of the first obstacle the flow is subcritical with a modulated undular bore attached to this first obstacle. Between the two obstacles there are interacting waves whose amplitudes are not decreasing and remain unsteady.
Simulations for
 $F=1.0,\unicode[STIX]{x1D6E5}=0,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.2$
.

In figure 10 we show the case when
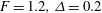 $F=1.2,\unicode[STIX]{x1D6E5}=0.2$
. The transition boundaries for the first obstacle are
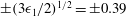 $\pm (3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=\pm 0.39$
and
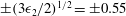 $\pm (3\unicode[STIX]{x1D716}_{2}/2)^{1/2}=\pm 0.55$
for the second obstacle, and so this flow is transcritical for both obstacles. Overall, the flow develops in a similar manner to that described above for
 $F=1$
in figure 2, and the first stage can be seen at
 $t=20,80$
. The second stage has already begun at
 $t=160$
. The beginning of the third stage can be seen at the time
 $t=3000$
. For the long run,
 $t=5900$
, the undular bore upstream of the first obstacle is modulated by the waves between the obstacles.
The case when
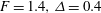 $F=1.4,\unicode[STIX]{x1D6E5}=0.4$
is shown in figure 11. Now, while the first obstacle is locally in a supercritical regime,
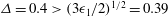 $\unicode[STIX]{x1D6E5}=0.4>(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=0.39$
, the second obstacle is still locally in the transcritical regime,
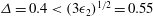 $\unicode[STIX]{x1D6E5}=0.4<(3\unicode[STIX]{x1D716}_{2})^{1/2}=0.55$
. This differs from the corresponding case for equal obstacle heights shown in figure 4. At the early times
 $t=80,120$
we see a locally steady supercritical flow over the first obstacle, while large-amplitude elevation waves generated by the second obstacle propagate upstream towards the first obstacle, and a weak undular bore propagates downstream. The upstream-propagating elevation waves continually generated at the second obstacle pass over the first obstacle and continue upstream.
Simulations for
 $F=1.2,\unicode[STIX]{x1D6E5}=0.2,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.2$
.

Simulations for
 $F=1.4,\unicode[STIX]{x1D6E5}=0.4,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.2$
.

Simulations for
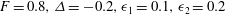 $F=0.8,\unicode[STIX]{x1D6E5}=-0.2,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.2$
.

The case when
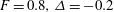 $F=0.8,\unicode[STIX]{x1D6E5}=-0.2$
is shown in figure 12. This flow is in the transcritical regime for both obstacles. But, the first obstacle is just below the regime boundary where the upstream undular bore is fully detached and the downstream undular bore is attached, that is
 $-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=-0.39<\unicode[STIX]{x1D6E5}=-0.2<-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}/2=-0.19$
, while the second obstacle is above this boundary, that is
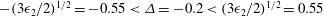 $-(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}=-0.55<\unicode[STIX]{x1D6E5}=-0.2<(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}=0.55$
and so the upstream undular bore is attached to the obstacle, while the downstream undular bore is detached. These features are apparent in the first stage,
 $t=40$
. In the second stage,
 $t=60,160$
there is an interaction between the downstream undular bore from the first obstacle and the upstream undular bore from the second obstacle, similar to the case of equal obstacle heights shown in figure 5. However, the third stage,
 $t=740,7400$
, is different since there is little sign of a depression behind the first obstacle. Critical control is exerted by the second obstacle. There is continuing wave interaction between the obstacles, which modulates the undular bore propagating upstream of the first obstacle.
The case of
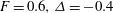 $F=0.6,\unicode[STIX]{x1D6E5}=-0.4$
is shown in figure 13. This flow is subcritical for the first obstacle as
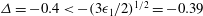 $\unicode[STIX]{x1D6E5}=-0.4<-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=-0.39$
but is transcritical for the second obstacle in the regime when the upstream undular bore is detached and the downstream undular is detached,
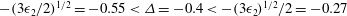 $-(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}=-0.55<\unicode[STIX]{x1D6E5}=-0.4<-(3\unicode[STIX]{x1D716}_{2})^{1/2}/2=-0.27$
. Overall the stages are similar to the case of equal obstacle heights shown in figure 6 except that the amplitude of the downstream undular bore downstream is larger due to the larger obstacle amplitude.
Simulations for
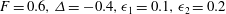 $F=0.6,\unicode[STIX]{x1D6E5}=-0.4,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.2$
.

Simulations for
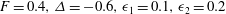 $F=0.4,\unicode[STIX]{x1D6E5}=-0.6,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.2$
.

The case of
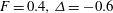 $F=0.4,\unicode[STIX]{x1D6E5}=-0.6$
is shown in figure 14. This flow is fully subcritical for both obstacles and is similar to the case of equal obstacle heights shown in figure 7.
3.4 Unequal obstacle heights
$(\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.05)$
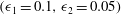
The case of
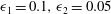 $\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.05$
for
 $F=1.0,\unicode[STIX]{x1D6E5}=0$
is shown in figure 15, where the second obstacle height is now smaller than the first obstacle height. The first two stages are similar to the case of equal obstacle heights shown in figure 1. However, as the third stage is approached , there is only a single wave between the obstacles at
 $t=5920$
and this wave then moves downstream over the second obstacle and passes very far downstream. Thus, there are eventually no waves between the obstacles and the flow is supercritical over the second obstacle.
Simulations for
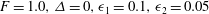 $F=1.0,\unicode[STIX]{x1D6E5}=0,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.05$
.

The case of
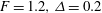 $F=1.2,\unicode[STIX]{x1D6E5}=0.2$
is shown in figure 16. This flow is transcritical for both obstacles,
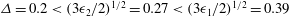 $\unicode[STIX]{x1D6E5}=0.2<(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}=0.27<(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=0.39$
. This is similar to the case of
 $F=1.2$
above in figure 15, but evolves faster as the supercritical flow over the second obstacle occurs at time
 $t=1360$
. Again this third stage differs from that for equal obstacle heights show in figure 2.
Simulations for
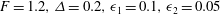 $F=1.2,\unicode[STIX]{x1D6E5}=0.2,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.05$
.

The case of
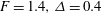 $F=1.4,\unicode[STIX]{x1D6E5}=0.4$
is shown in figure 17. This flow is supercritical for both obstacles,
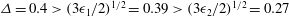 $\unicode[STIX]{x1D6E5}=0.4>(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=0.39>(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}=0.27$
. The flow is fully developed supercritical flow over the obstacles, similar to that for equal obstacles shown in figure 4.
Simulations for
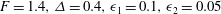 $F=1.4,\unicode[STIX]{x1D6E5}=0.4,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.05$
.

The case of
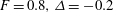 $F=0.8,\unicode[STIX]{x1D6E5}=-0.2$
is shown in figure 18. This flow is transcritical for the both obstacles, and both obstacles are in the regime where the upstream undular bore is attached and the downstream undular bore is detached,
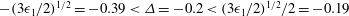 $-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=-0.39<\unicode[STIX]{x1D6E5}=-0.2<(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}/2=-0.19$
and
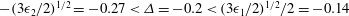 $-(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}=-0.27<\unicode[STIX]{x1D6E5}=-0.2<(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}/2=-0.14$
. The first two stages are similar to the case of equal obstacle heights shown in figure 5. But the third stage is different as now the waves between the obstacles can eventually disappear, leaving a locally supercritical flow over the first obstacle terminated by an upstream-propagating undular bore (see
 $t=200$
) which is far upstream at
 $t=2540,7780$
, and an attached undular bore downstream of the second obstacle.
Simulations for
 $F=0.8,\unicode[STIX]{x1D6E5}=-0.2,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.05$
.

Simulations for
 $F=0.6,\unicode[STIX]{x1D6E5}=-0.4,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.05$
.

The case of
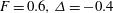 $F=0.6,\unicode[STIX]{x1D6E5}=-0.4$
is shown in figure 19. This flow is subcritical for both obstacles,
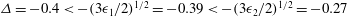 $\unicode[STIX]{x1D6E5}=-0.4<-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}=-0.39<-(3\unicode[STIX]{x1D716}_{2}/2)^{1/2}=-0.27$
. The first two stages are similar to the case of equal obstacles shown in figure 6. But at the third stage, steady lee waves form behind both obstacles and a small depression can be seen behind the first obstacle.
Simulations for
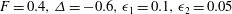 $F=0.4,\unicode[STIX]{x1D6E5}=-0.6,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.05$
.

The case of
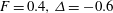 $F=0.4,\unicode[STIX]{x1D6E5}=-0.6$
shown in figure 20 and is also fully subcritical for both obstacles. This case is similar to that for equal obstacle heights shown in figure 7 and the flow develops rapidly into locally steady subcritical flow over both obstacles.
4 Discussion
Our aim in this paper is to study free-surface flow over two localised obstacles, with the emphasis on the transcritical regime when the Froude number
 $F\approx 1$
. In the weakly nonlinear long-wave regime the forced Korteweg–de Vries equation (2.1) is the appropriate model. In this framework, the flow can be characterised by
 $\unicode[STIX]{x1D6E5}$
,
 $\unicode[STIX]{x1D6E5}=F-1$
and the maximum heights of each obstacle,
 $\unicode[STIX]{x1D716}_{1}$
and
 $\unicode[STIX]{x1D716}_{2}$
, where the index
 $1,2$
denote the first and second obstacles respectively. The initial condition is a flat surface, into which both obstacles are suddenly introduced. In the transcritical regime, it is well known from asymptotic theory based on the Whitham modulation theory and numerical simulations (see Grimshaw & Smyth (Reference Grimshaw and Smyth1986), Grimshaw (Reference Grimshaw2010)) that flow over a single localised obstacle will produce undular bores upstream and downstream of the obstacle. This is the first stage in the present numerical simulations, but in the second stage, the undular bore downstream of the first obstacle will interact with the undular bore upstream of the first obstacle. The third and final stage is the very large time evolution and the main issue is whether the first or the second obstacle has exerted critical control of the flow. Our results indicate that this criticality is controlled by the parameters
 $\unicode[STIX]{x1D716}_{1}$
,
 $\unicode[STIX]{x1D716}_{2}$
and
 $\unicode[STIX]{x1D6E5}$
. For equal obstacle heights,
 $\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}$
, when
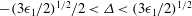 $-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}/2<\unicode[STIX]{x1D6E5}<(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}$
the first obstacle controls the flow, with locally transcritical flow over the first obstacle, and supercritical flow over the second obstacle. On the other hand, when
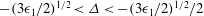 $-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}<\unicode[STIX]{x1D6E5}<-(3\unicode[STIX]{x1D716}_{1}/2)^{1/2}/2$
, the second obstacle exerts control, with locally transcritical flow over the second obstacle, and subcritical flow over the first obstacle. However, in the transcritical regime, there is continuing wave interaction between the two obstacles. When the obstacle heights are not equal, then the larger obstacle controls criticality. This flow behaviour differs from our recent work (Grimshaw & Maleewong Reference Grimshaw and Maleewong2015) using the fully nonlinear but non-dispersive wave shallow water wave model where it was found in the case of equal obstacle heights
 $\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}$
that criticality is controlled by the second obstacle, although as here, it was found that criticality is controlled by the larger obstacle height when
 $\unicode[STIX]{x1D716}_{1}\neq \unicode[STIX]{x1D716}_{2}$
. But importantly in this present work using the fKdV equation, which includes wave dispersion, the shock dynamics in Grimshaw & Maleewong (Reference Grimshaw and Maleewong2015) is replaced here by undular bores and nonlinearly interacting waves.
We note the recent studies of Dias & Vanden-Broeck (Reference Dias and Vanden-Broeck2004), Binder et al. (Reference Binder, Vanden-Broeck and Dias2005, Reference Binder, Dias and Vanden-Broeck2006), Ee & Clarke (Reference Ee and Clarke2007), Donahue & Shen (Reference Donahue and Shen2010), Ee et al. (Reference Ee, Grimshaw, Zhang and Chow2010, Reference Ee, Grimshaw, Chow and Zhang2011), Chardard et al. (Reference Chardard, Dias, Nguyen and Vanden-Broeck2011) who examined the possible presence of steady solutions containing trapped waves between the two obstacles. The results reported here vary only three of the available parameters, namely
 $\unicode[STIX]{x1D6E5}$
,
 $\unicode[STIX]{x1D716}_{1,2}$
and in particular keep the shape and the distance between the obstacles fixed. As a result, in all our simulations except one, the waves existing between the two obstacles continued to be unsteady even for very long simulations. An exception may be in figure 19 for
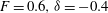 $F=0.6,\unicode[STIX]{x1D6FF}=-0.4$
and
 $\unicode[STIX]{x1D716}_{1}=0.1$
,
 $\unicode[STIX]{x1D716}_{2}=0.005$
, although here there are also steady lee waves downstream of the second obstacle, and the steady waves between the obstacles may be just a steady lee wave train associated with the first obstacle continuing past the second obstacle with possibly even a different wavenumber; that is, they are not trapped. However, as noted in the aforementioned references, especially by Dias & Vanden-Broeck (Reference Dias and Vanden-Broeck2004), Binder et al. (Reference Binder, Vanden-Broeck and Dias2005), Ee & Clarke (Reference Ee and Clarke2007), Ee et al. (Reference Ee, Grimshaw, Zhang and Chow2010, Reference Ee, Grimshaw, Chow and Zhang2011), steady waves trapped between the two obstacles can be found using a larger parameter space, and in particular, by allowing a variation of the distance between the obstacles. This implies that they are very unlikely to be found here with the generic values of
 $\unicode[STIX]{x1D6E5}$
,
 $\unicode[STIX]{x1D716}_{1}$
and
 $\unicode[STIX]{x1D716}_{2}$
we have used.
Simulations for
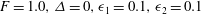 $F=1.0,\unicode[STIX]{x1D6E5}=0,\unicode[STIX]{x1D716}_{1}=0.1,\unicode[STIX]{x1D716}_{2}=0.1$
.

Motivated by this discussion, we carried out some further simulations in which the obstacle widths are varied. As shown in figure 1, we cannot find locally steady transcritical flow at
 $F=1$
for equal obstacle heights and widths. But by varying the widths of obstacle, we have found one such locally steady solution. We set
 $\unicode[STIX]{x1D716}_{1}=\unicode[STIX]{x1D716}_{2}=0.1$
, but the width of the first obstacle is
 $w=1000$
while for the second obstacle is
 $w=10$
, so that the first obstacle is much wider than the second obstacle. The simulation results are shown in figure 21. The first stage behaviour
 $(t=70)$
is explained again by the theory for a single obstacle. In the second stage,
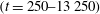 $(t=250{-}13\,250)$
, there are wave interactions between the obstacles but the number of waves between the obstacles decreases as time increases. Some waves between the obstacles can pass over the first obstacle and travel further upstream. Some waves travel back and can pass the trapped elevation wave over the second obstacle. Finally, after a very long time,
 $t=17\,390$
the waves between the obstacle are diminished and seem to have been extinguished completely. The same behaviour was found when
 $w=500$
at the first obstacle, but if the obstacles are reversed, so that the second obstacle is the wider one, then no such steady solutions could be found. Clearly, by extending the parameter space in this way, more different types of solutions can be found, and in particular a search for steady trapped waves will continue.
Acknowledgements
The first author (R.H.J.G.) is a Leverhulme Emeritus Fellow and acknowledges the support of the Leverhulme Trust. The second author (M.M.) is supported by the Thailand Research Fund (TRF) under the grant no. RSA5680038.
Appendix A. Undular bore
We consider the unforced KdV equation where
 $f(x)=0$
in (2.1),
 $$\begin{eqnarray}-\unicode[STIX]{x1D701}_{t}-\unicode[STIX]{x1D6E5}\unicode[STIX]{x1D701}_{x}+{\textstyle \frac{3}{2}}\unicode[STIX]{x1D701}\unicode[STIX]{x1D701}_{x}+{\textstyle \frac{1}{6}}\unicode[STIX]{x1D701}_{xxx}=0,\end{eqnarray}$$
with the initial jump condition
 $$\begin{eqnarray}\unicode[STIX]{x1D701}=\unicode[STIX]{x1D701}_{0}H(x),\quad \unicode[STIX]{x1D701}_{0}>0.\end{eqnarray}$$
Here
 $H(x)$
is the usual Heaviside function. Using the Whitham modulation theory, see Whitham (Reference Whitham1965, Reference Whitham1974), Gurevich & Pitaevskii (Reference Gurevich and Pitaevskii1974), Fornberg & Whitham (Reference Fornberg and Whitham1978). the undular bore is represented by the modulated periodic wavetrain
 $$\begin{eqnarray}\unicode[STIX]{x1D701}=a\{b(m)+\text{cn}^{2}(\unicode[STIX]{x1D705}(x-Vt);m)\}+d,\end{eqnarray}$$
where
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}b={\displaystyle \frac{1-m}{m}}-{\displaystyle \frac{E(m)}{mK(m)}},\quad a={\displaystyle \frac{4m\unicode[STIX]{x1D705}^{2}}{3}},\\ \text{and}\quad V=\unicode[STIX]{x1D6E5}-{\displaystyle \frac{3d}{2}}-{\displaystyle \frac{a}{2}}\left\{{\displaystyle \frac{2-m}{m}}-{\displaystyle \frac{3E(m)}{mK(m)}}\right\}.\end{array}\right\}\end{eqnarray}$$
Here
 $\text{cn}(x;m)$
is the Jacobi elliptic function of modulus
 $m$
and
 $K(m),E(m)$
are the elliptic integrals of the first and second kind, respectively. (
 $0<m<1$
),
 $a$
is the wave amplitude,
 $d$
is the mean level and
 $V$
is the wave speed. The spatial period is
 $2K(m)/\unicode[STIX]{x1D705}$
. This family of solutions contains three free parameters, which are chosen from the set
 $\{a,\unicode[STIX]{x1D705},V,d,m\}$
. As
 $m\rightarrow 1$
,
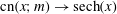 $\text{cn}(x;m)\rightarrow \text{sech}(x)$
and then the cnoidal wave (A 3) becomes a solitary wave, riding on a background level
 $d$
. On the other hand, as
 $m\rightarrow 0$
,
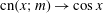 $\text{cn}(x;m)\rightarrow \cos x$
and so the cnoidal wave (A 3) collapses to a linear sinusoidal wave of small amplitude
 $a\sim m$
).
In the aforementioned asymptotic method in the modulated periodic wavetrain, the amplitude
 $a$
, the mean level
 $d$
, the speed
 $V$
and the wavenumber
 $\unicode[STIX]{x1D705}$
are all slowly varying functions of
 $x$
and
 $t$
, described by a set of three nonlinear hyperbolic equations for three of the available free parameters, chosen from the set
 $(a,\unicode[STIX]{x1D705},V,d,m)$
. Here the relevant asymptotic solution is constructed in terms of the similarity variable
 $x/t$
,
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D6E5}-\frac{x}{t}=\frac{\unicode[STIX]{x1D701}_{0}}{2}\left\{1+m-\frac{2m(1-m)K(m)}{E(m)-(1-m)K(m)}\right\},\quad -\frac{3\unicode[STIX]{x1D701}_{0}}{2}<\unicode[STIX]{x1D6E5}-\frac{x}{t}<\unicode[STIX]{x1D701}_{0}, & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a=2\unicode[STIX]{x1D701}_{0}m,\quad d=\unicode[STIX]{x1D701}_{0}\left\{m-1+\frac{2E(m)}{K(m)}\right\}. & & \displaystyle\end{eqnarray}$$
Ahead of the wavetrain where
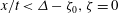 $x/t<\unicode[STIX]{x1D6E5}-\unicode[STIX]{x1D701}_{0},\unicode[STIX]{x1D701}=0$
and at this end,
 $m\rightarrow 1$
,
 $a\rightarrow 2\unicode[STIX]{x1D701}_{0}$
and
 $d\rightarrow 0$
; the leading wave is a solitary wave of amplitude
 $2\unicode[STIX]{x1D701}_{0}$
relative to a mean level of
 $0$
. Behind the wavetrain where
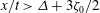 $x/t>\unicode[STIX]{x1D6E5}+3\unicode[STIX]{x1D701}_{0}/2$
,
 $\unicode[STIX]{x1D701}=\unicode[STIX]{x1D701}_{0}$
and at this end
 $m\rightarrow 0$
,
 $a\rightarrow 0$
, and
 $d\rightarrow \unicode[STIX]{x1D701}_{0}$
; the wavetrain is now sinusoidal with a wavenumber
 $\unicode[STIX]{x1D705}$
given by
 $\unicode[STIX]{x1D705}^{2}=3\unicode[STIX]{x1D701}_{0}/2$
; indeed this holds throughout the wavetrain, so all waves have the same spatial wavelength.
The corresponding solution when the initial condition is instead
 $$\begin{eqnarray}\unicode[STIX]{x1D701}=-\unicode[STIX]{x1D701}_{0}H(-x),\end{eqnarray}$$
can be obtained from the above by the transformation
 $$\begin{eqnarray}\tilde{\unicode[STIX]{x1D701}}=\unicode[STIX]{x1D701}+\unicode[STIX]{x1D701}_{0},\quad \tilde{x}=x-\frac{3\unicode[STIX]{x1D701}_{0}}{2}t,\end{eqnarray}$$
which transforms the initial value problem (A 7) for
 $\unicode[STIX]{x1D701}$
satisfying (A 1) into the initial value problem (A 2) for
 $\tilde{\unicode[STIX]{x1D701}}$
also satisfying (A 1).



