




No CrossRef data available.
Article contents
An improved FastSLAM 2.0 algorithm based on FC&ASD-PSO
Published online by Cambridge University Press: 09 August 2016
Summary
Core share and HTML view are not available for this content. However, as you have access to this content, a full PDF is available via the 'Save PDF' action button.
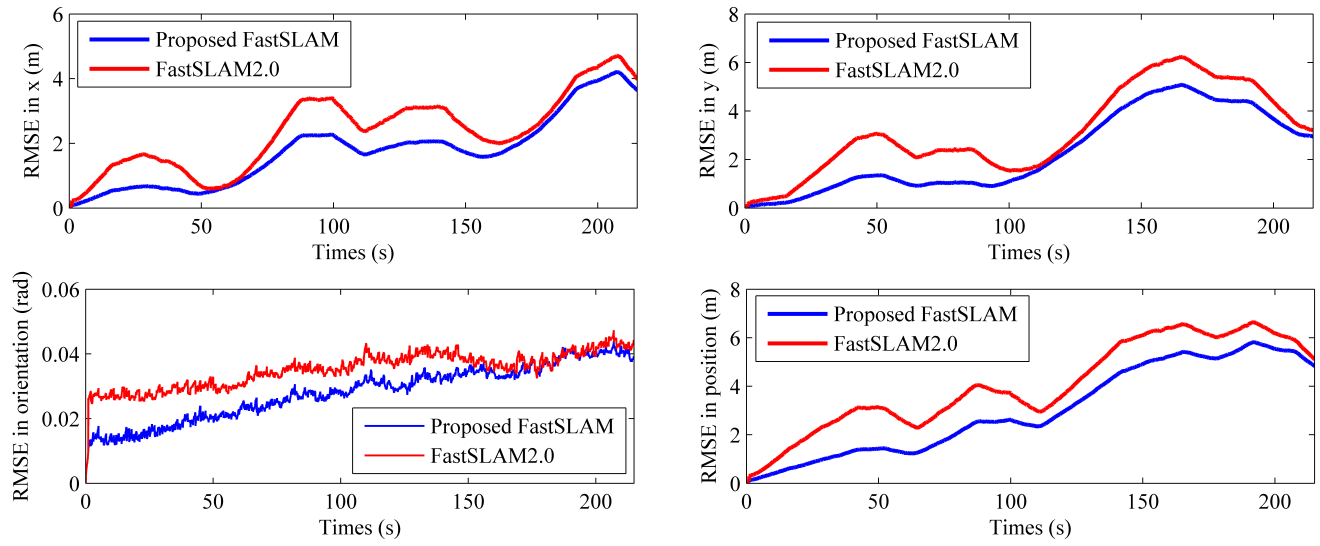
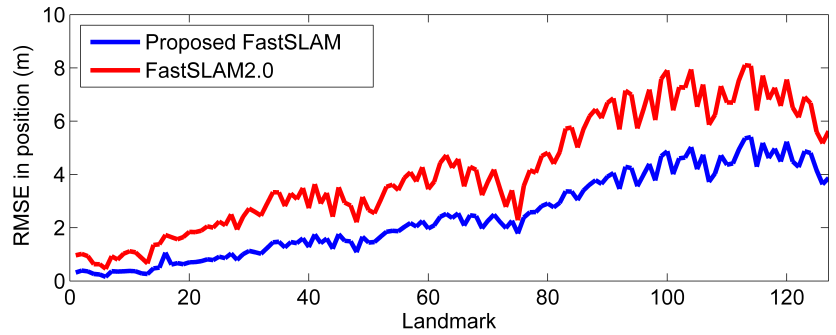
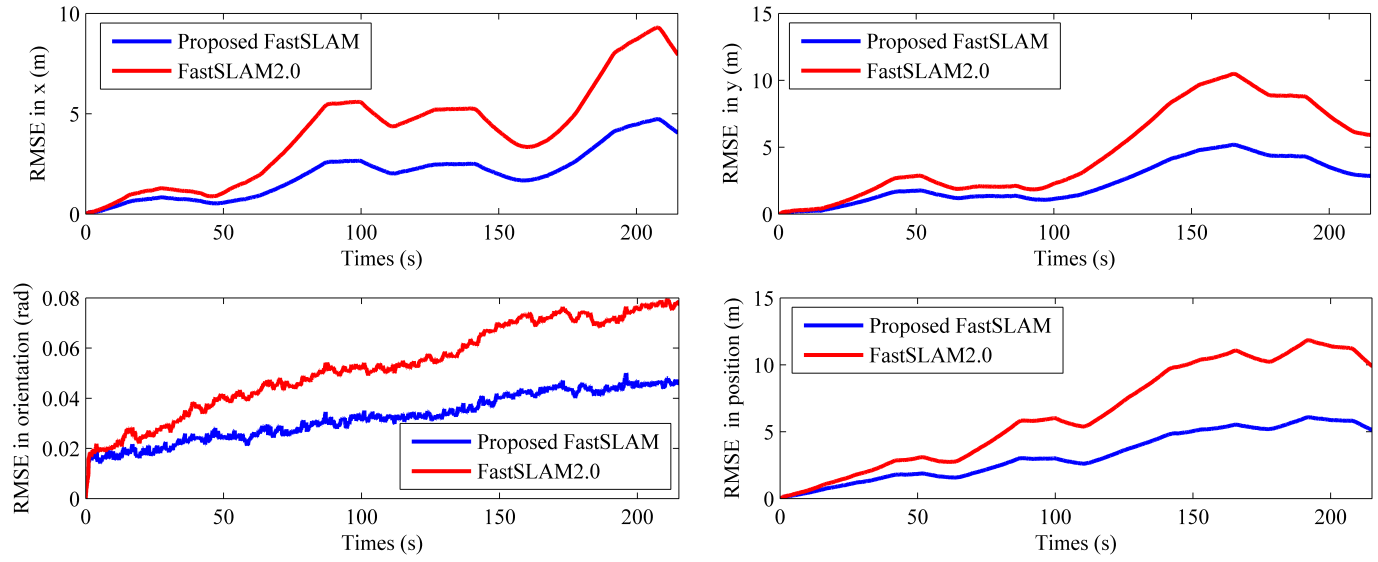
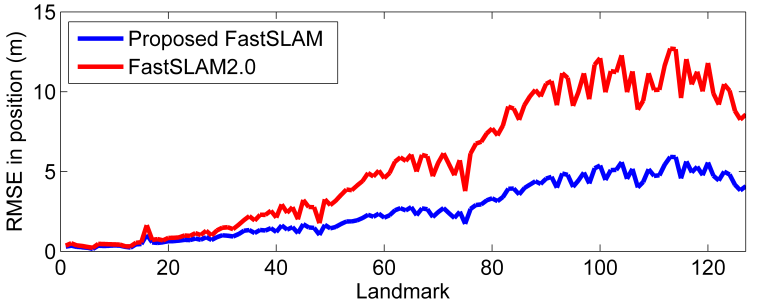
FastSLAM 2.0 is a popular framework which uses a Rao-Blackwellized particle filter to solve the simultaneous localization and mapping problem. The sampling process is one of the most important phases in the FastSLAM 2.0 framework. Its estimation accuracy depends heavily on a correct prior knowledge about the control and observation noise statistics (the covariance matrices Q and R). Without the correct prior knowledge about these matrices, the estimation accuracy of the robot path and landmark positions may degrade seriously. However in many applications, the prior knowledge is unknown, or these noises are non-stationary. In this paper, these covariance matrices are supposed to be dynamic and denoted as Q t and R t . Since there are noises, time-adjacent observations are inconsistent with each other. This inconsistency can reflect the real value of the covariance matrices. By the inconsistency, an extra step is introduced to the FastSLAM 2.0 framework. This step makes Q t and R t match with their real value by using a particle swarm optimization method based on fractional calculus and alpha stable distribution (FC&ASD-PSO). Both simulation and experimental results show that the proposed algorithm improves the accuracy by the more accurate estimation on the noise covariance matrices.
Keywords
Information
- Type
- Articles
- Information
- Copyright
- Copyright © Cambridge University Press 2016
References
1.
Fernández-Madrigal, J. A. and Claraco, J. B., Simultaneous Localization and Mapping for Mobile Robots: Introduction and Methods (IGI Global, Hershey, 2013).CrossRefGoogle Scholar
2.
Fischer, C., Localisation, Tracking, and Navigation Support for Pedestrians in Uninstrumented and Unknown Environments Ph.D. Thesis (Lancaster University, Lancaster, UK, 2012).Google Scholar
3.
Durrant-Whyte, H. and Bailey, T., “Simultaneous localization and mapping: Part I,” Robot. Autom. Mag.
24
(2), 99–110 (2006).CrossRefGoogle Scholar
4.
Kurt-Yavuz, Z. and Yavuz, S., “A Comparison of EKF, UKF, FastSLAM2.0, and UKF-Based FastSLAM Algorithms,” Proceedings of the IEEE International Conference on Intelligent Engineering Systems, Lisboa, Portugal (2012) pp. 37–43.Google Scholar
5.
Montemerlo, M., FastSLAM: A Factored Solution to the Simultaneous Localization and Mapping Problem with Unknown Data Association Ph.D. Thesis (Carnegie Mellon University, Pittsburgh, USA, 2003).Google Scholar
6.
Dellaert, F. and Kaess, M., “Square root SAM: Simultaneous localization and mapping via square root information smoothing,” Int. J. Robot. Res.
25
(12), 1181–1203 (2006).Google Scholar
7.
Thrun, S. and Montemerlo, M., “The GraphSLAM algorithm with application to large-scale mapping of urban structures,” Int. J. Robot. Res.
25
(5–6), 403–429 (2006).Google Scholar
8.
Martinez-Cantin, R., Freitas, N. D. and Castellanos, J. A., “Analysis of Particle Methods for Simultaneous Robot Localization and Mapping and a New Algorithm: Marginal-SLAM,” Proceedings of the IEEE International Conference on Robotics and Automation, Roma, Italy (2007) pp. 2415–2420.Google Scholar
9.
Grisetti, G., Stachniss, C. and Burgard, W., “Improved techniques for grid mapping with Rao-Blackwellized particle filters,” Robotics, 32
(1), 34–46 (2007).Google Scholar
10.
Chen, Z., Dai, X., Jiang, L. H., Yang, C. and Cai, B., “Adaptive iterated square-root cubature Kalman filter and its application to SLAM of a mobile robot,” Telkomnika Indonesian J. Electr. Eng.
11
(12), 7213–7221 (2013).Google Scholar
11.
Ruben, M. C. and Castellanos, J. A., “Unscented SLAM for Large-Scale Outdoor Environments,” Proceedings of the IEEE International Conference on Intelligent Robots and Systems, Victoria, Canada (2005) pp. 3427–3432.Google Scholar
12.
Gamallo, C., Mucientes, M. and Regueiro, C. V., “A FastSLAM-based algorithm for omni directional cameras,” J. Phys. Agents
7
(1), 12–21 (2012).Google Scholar
13.
Chen, S. M., Yuan, J. F., Zhang, F. and Fang, H. J., “Multirobot FastSLAM algorithm based on landmark consistency correction,” Math. Probl. Eng.
2014, 1–7 (2014).Google Scholar
14.
Bailey, T., Nieto, J. and Nebot, E., “Consistency of the FastSLAM Algorithm,” Proceedings of the IEEE International Conference on Robotics and Automation, Orlando, Florida (2006) pp. 424–429.Google Scholar
15.
Stachniss, C., Grisetti, G., Hhnel, D. and Burgard, W., “Improved Rao-Blackwellized Mapping by Adaptive Sampling and Active Loop-closure,” Proceedings of the Workshop on Self-Organization of Adaptive Behavior, Ilmenau, Germany (2004) pp. 1–15.Google Scholar
16.
Nosan, N., Kim, I. K., Lee, H. C. and Lee, B. H., “Analysis of Resampling Process for the Particle Depletion Problem in FastSLAM,” Proceedings of the IEEE International Conference on Robot and Human interactive Communication, Jeju, Korea (2007) pp. 200–205.Google Scholar
17.
Zhou, W. and Zhao, C. X., “A FastSLAM 2.0 algorithm based on genetic algorithm,” Robotics, 31
(1), 25–32 (2009).Google Scholar
18.
Wang, H., Yan, Y. and Wang, D. W., “A GA Based SLAM with Range Sensors Only,” Proceedings of the IEEE International Conference on Control, Automation, Robotics and Vision, Singapore (2010) pp. 1796–1803.Google Scholar
19.
Kim, C., Sakthivel, R. and Chung, W. K., “Unscented FastSLAM: A robust and efficient solution to the SLAM problem,” Robotics, 24
(4), 808–820 (2008).Google Scholar
20.
Liu, D., Liu, G. R. and Yu, M. H., “An improved FastSLAM framework based on particle swarm optimization and unscented particle filter,” J. Comput. Inf. Syst.
8
(7), 2859–2866 (2012).Google Scholar
21.
Havangi, R., Taghirad, H. D., Nekoui, M. A. and Teshnehlab, M., “A square root unscented FastSLAM with improved proposal distribution and resampling,” Ind. Electron.
61
(5), 2334–2345 (2014).Google Scholar
22.
Zhu, J. H., Zhang, N. N. and Yang, Z. J., “A SLAM algorithm based on central difference particle filter,” Acta Autom. Sin.
36
(2), 249–257 (2010).CrossRefGoogle Scholar
23.
Song, Y., Song, Y. D. and Li, Q. L., “Robust iterated sigma point FastSLAM algorithm for mobile robot simultaneous localization and mapping,” Chin. J. Mech. Eng.
24
(4), 1–8 (2011).CrossRefGoogle Scholar
24.
Yan, X. J., Zhao, C. X. and Xiao, J. Z., “A Novel FastSLAM Algorithm Based on Iterated Unscented Kalman Filter,” Proceedings of the IEEE International Conference on Robotics and Biometrics, Phuket, Thailand (2011) pp. 1906–1911.Google Scholar
25.
Havangi, R., Teshnelab, M., Nekoui, M. A. and Taghirad, H., “An Adaptive Neuro-Fuzzy Rao-Blackwellized Particle Filter for SLAM,” Proceedings of the IEEE International Conference on Mechatronics, Istanbul, Turkey (2011) pp. 487–492.Google Scholar
26.
Lv, T. Z., “A novel EKF-SLAM algorithm against outlier disturbance,” Comput. Eng.
38
(21), 1–4 (2012).Google Scholar
27.
Fitzgerald, R. J., “Divergence of the Kalman filter,” Autom. Control, 16
(6), 736–747 (1971).Google Scholar
28.
Li, X. D. and Engelbrecht, A. P., “Particle Swarm Optimization: An Introduction and its Recent Developments,” Proceedings of the Genetic Evolutionary Computation Conference, London, England (2007) pp. 3391–3414.Google Scholar
29.
Havangi, R., Nekoui, M. A. and Teshnehlab, M., “An improved FastSLAM framework using soft computing,” Turk. J. Electr. Eng. Comput. Sci.
20
(1), 25–46 (2012).Google Scholar
30.
Lee, H. C., Park, S. K. and Choi, J. S., “PSO-FastSLAM: An Improved FastSLAM Framework Using Particle Swarm Optimization,” Proceedings of the IEEE International Conference on Systems, Man and Cybernetics, San Antonio, Texas (2009) pp. 2763–2768.Google Scholar
31.
Davey, S. J., “Extensions to the Probabilistic Multi-Hypothesis Tracker for Improved Data Association,” Ph.D. Thesis (University of Adelaide, Lancaster, UK, 2003).Google Scholar
32.
Montemerlo, M., Thrun, S., Koller, D. and Wegbreit, B., “FastSLAM: A Factored Solution to the Simultaneous Localization and Mapping Problem,” Proceedings of the AAAI National Conference on Artificial Intelligence, Edmonton, Canada (2002) pp. 593–598.Google Scholar
33.
Montemerlo, M., Thrun, S., Koller, D. and Wegbreit, B., “FastSLAM 2.0: An Improved Particle Filtering Algorithm for Simultaneous Localization and Mapping that Provably Converges,” Proceedings of the International Joint Conference on Artificial Intelligence, Acapulco, Mexico (2003) pp. 1151–1156.Google Scholar
34.
Kennedy, J. and Eberhart, R., “Particle Swarm Optimization,” Proceedings of the IEEE International Conference on Neural Networks, Perth, Australia (1995) pp. 1942–1948.Google Scholar
35.
Hamta, N., Ghomi, S. F., Jolai, F. and Shirazi, M. A., “A hybrid PSO algorithm for a multi-objective assembly line balancing problem with flexible operation times, sequence-dependent setup times and learning effect,” Int. J. Prod. Econ.
141, 99–111 (2013).CrossRefGoogle Scholar
36.
Selvakumar, A. I. and Thanushkodi, K., “A new particle swarm optimization solution to nonconvex economic dispatch problems,” IEEE Trans. Power Syst.
22
(1), 42–51 (2007).Google Scholar
37.
Machado, J. T., Kiryakova, V. and Mainardi, F., “Recent history of fractional calculus,” Commun. Nonlinear Sci. Numer. Simul.
16
(3), 1140–1153 (2011).CrossRefGoogle Scholar
39.
Fourie, P. C. and Groenwold, A. A., “The particle swarm optimization algorithm in size and shape optimization,” Struct. Multidiscip. Optim.
23, 259–267 (2002).Google Scholar
40.
Weron, A. and Weron, R., Computer Simulation of Lévy α-stable Variables and Processes (Berlin, Springer, 1995).Google Scholar
41.
Woodman, O. J., “An Introduction to Inertial Navigation,” Technical Report UCAM-CL-TR-696 (University of Cambridge, Cambridge, UK, 2007).Google Scholar
42.
Nordh, J. and Berntorp, K., “Extending the Occupancy Grid Concept for Low-Cost Sensor Based SLAM,” Proceedings of the 10th IFAC Symposium on Robot Control, Dubrovnik, Croatia (2012) pp. 151–156.Google Scholar
43.
Cui, Z., Zeng, J. and Sun, G., “Lévy velocity threshold particle swarm optimization,” ICIC Express Lett.
2
(1), 23–28 (2008).Google Scholar
44.
Bailey, T., “FastSLAM 2.0 source code,” http://www.personal.acfr.usyd.edu.au/tbailey/software/index.html.Google Scholar
45.
Nebot, E., Guivant, J. and Nieto, J., “ACFR, experimental outdoor dataset,” http://www.acfr.usyd.edu.au/homepages/academic/enebot/dataset.htm.Google Scholar

Lv and Feng supplementary material
Figure 1
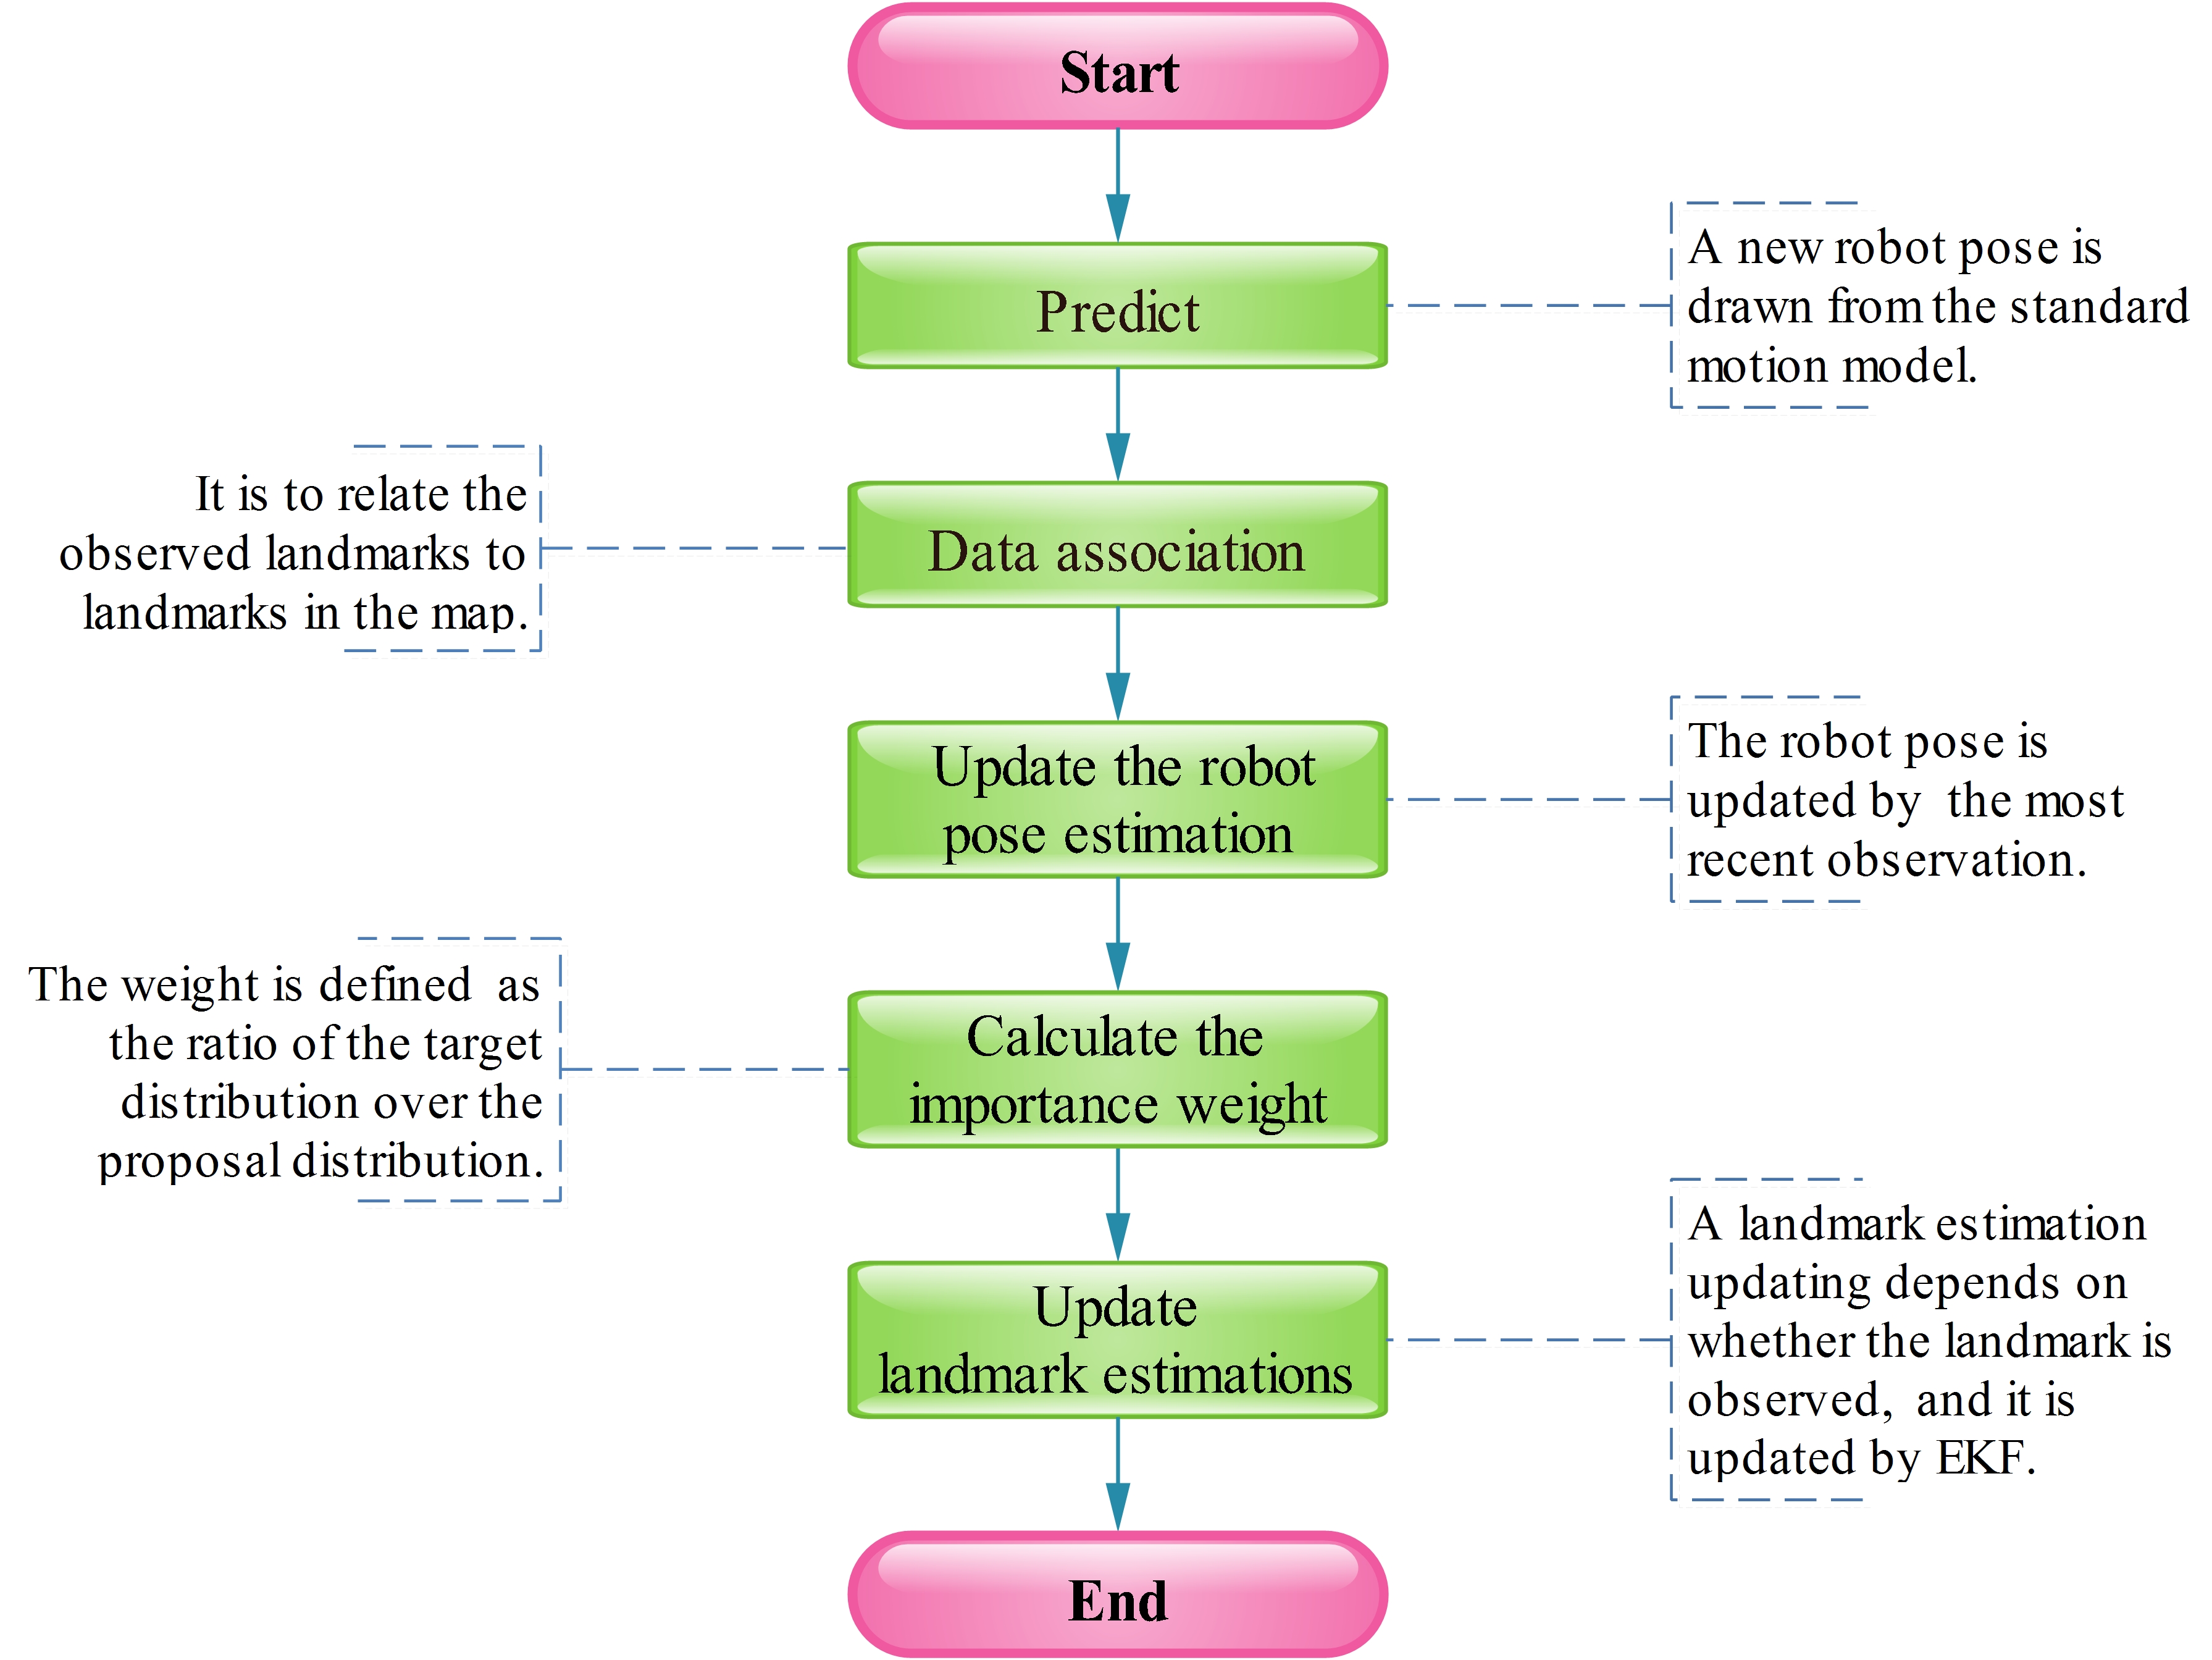
Image
1.6 MB
Lv and Feng supplementary material
Figure 2
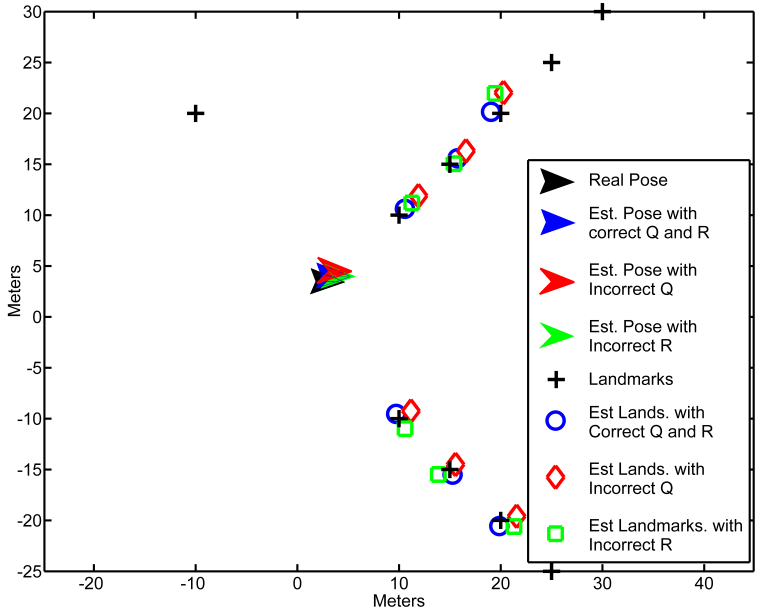
Image
51.9 KB
Lv and Feng supplementary material
Figure 3
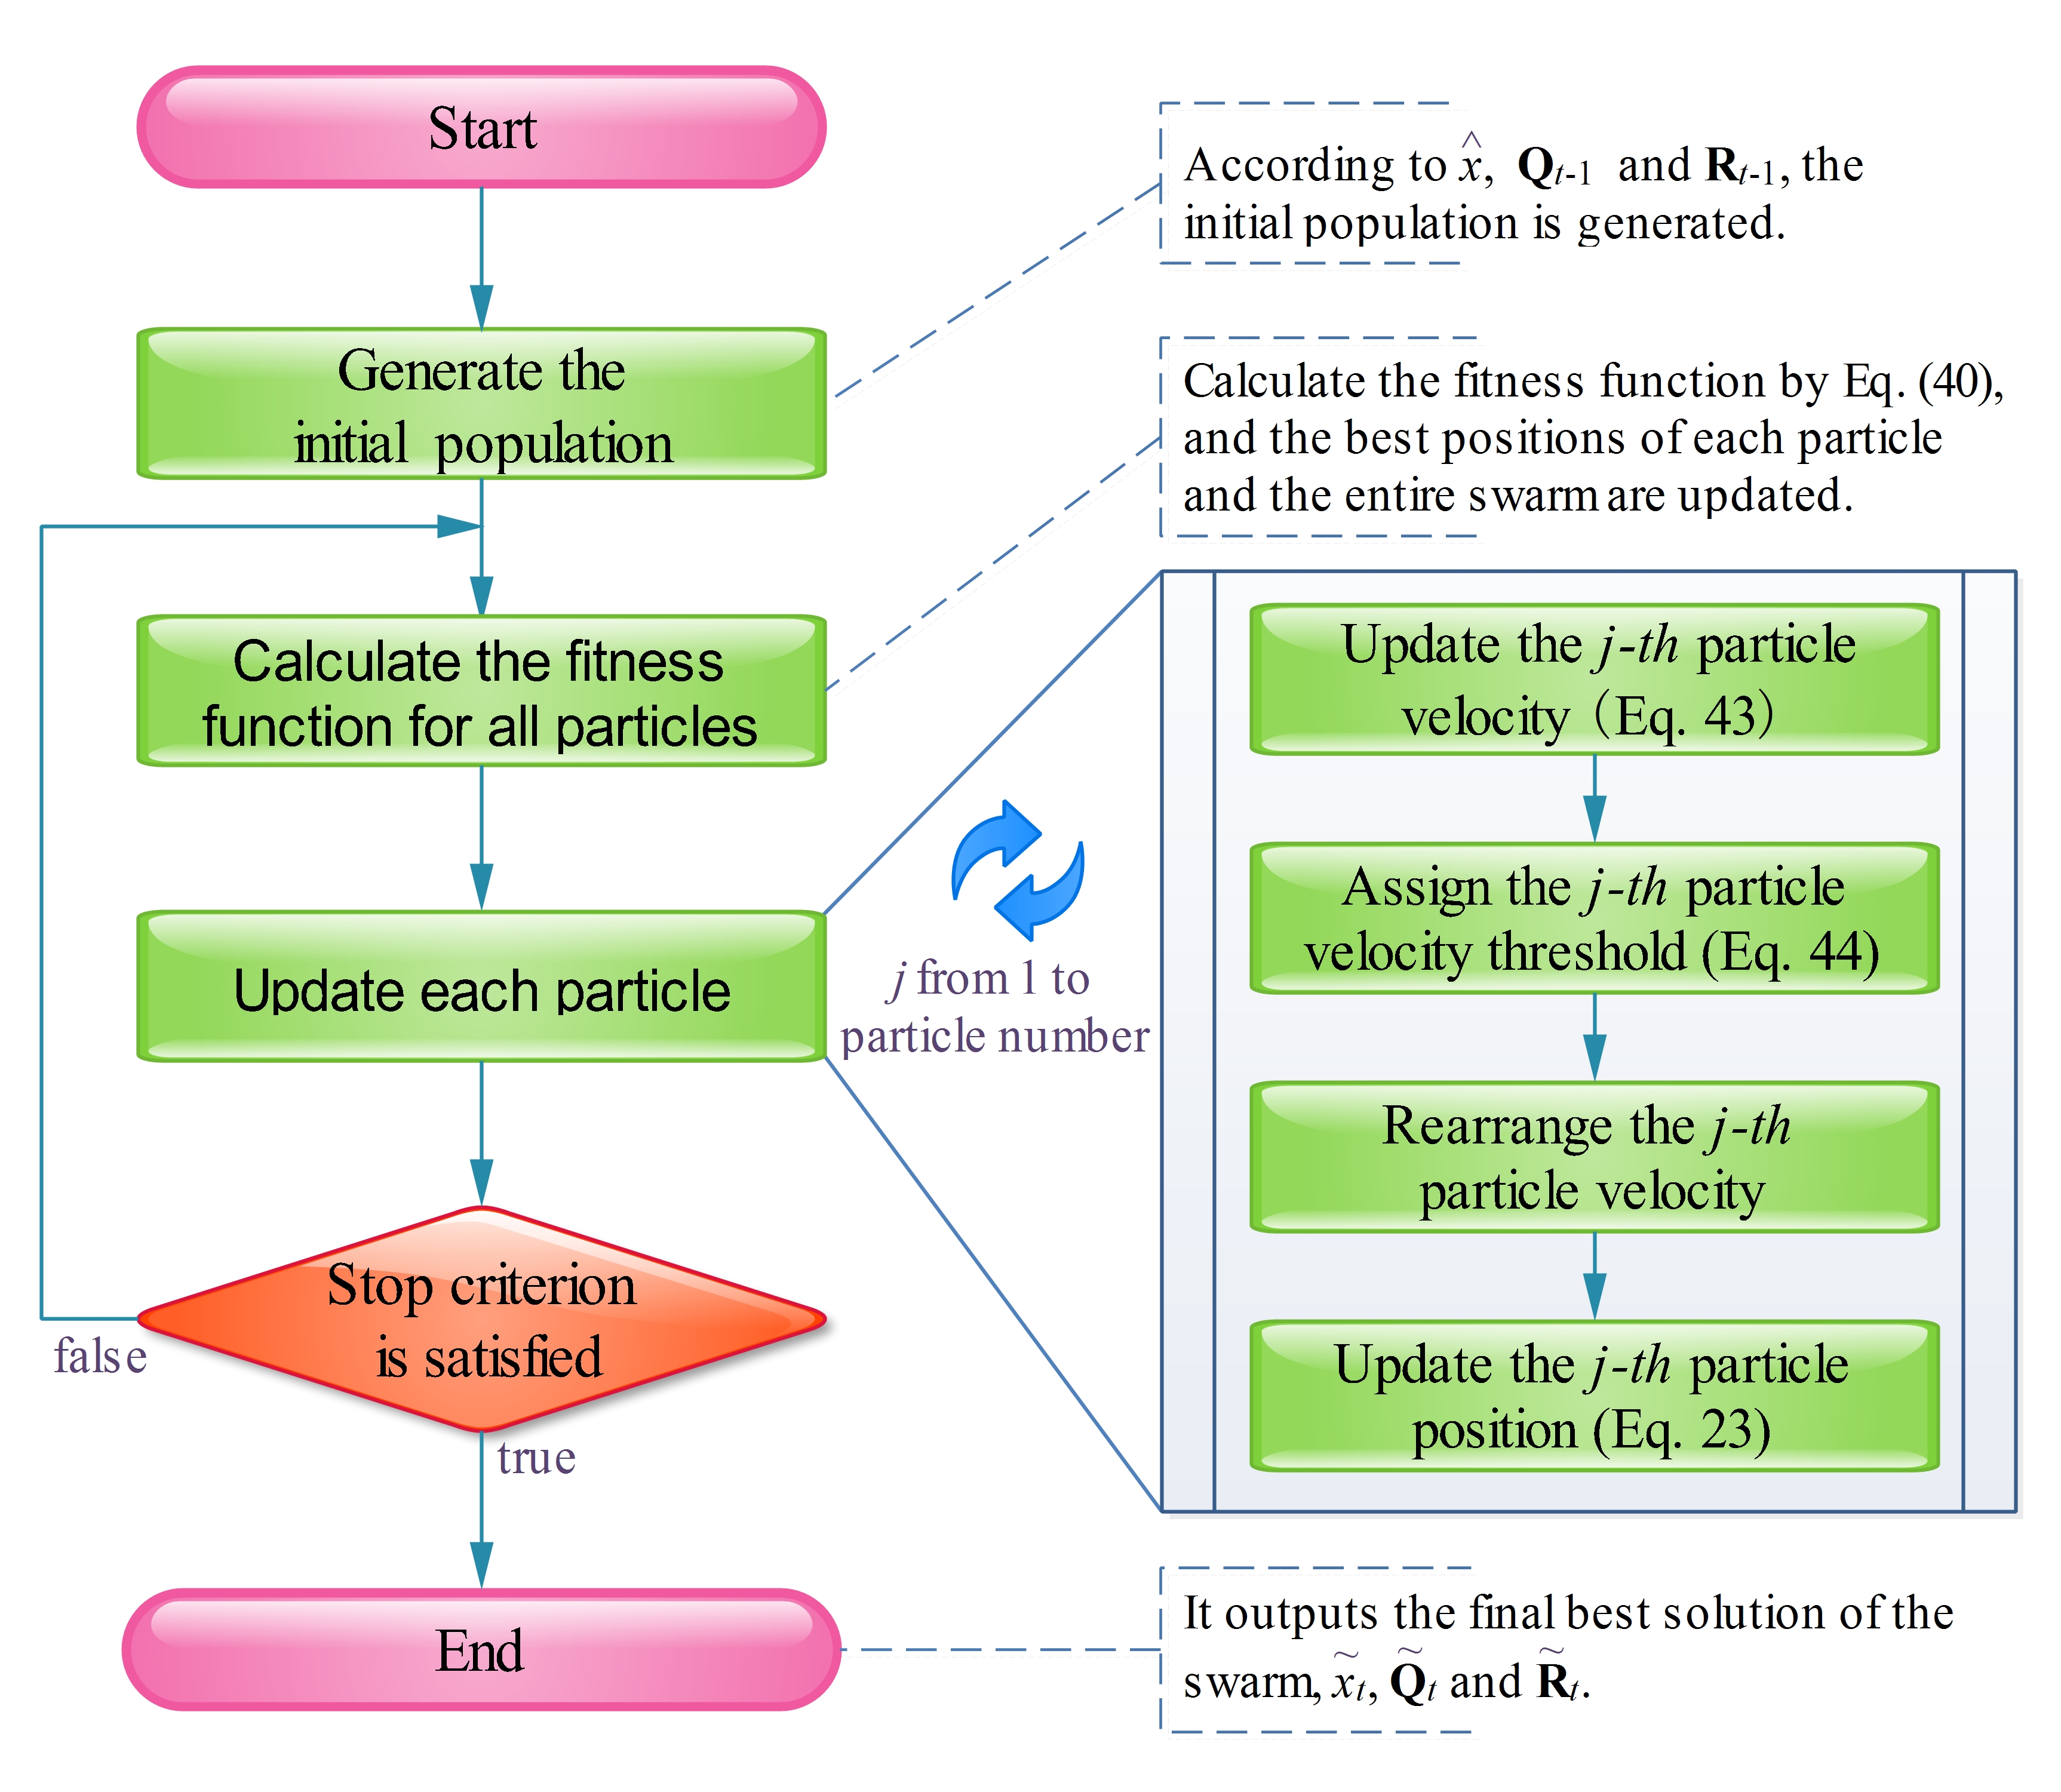
Image
2.2 MB
Lv and Feng supplementary material
Figure 4
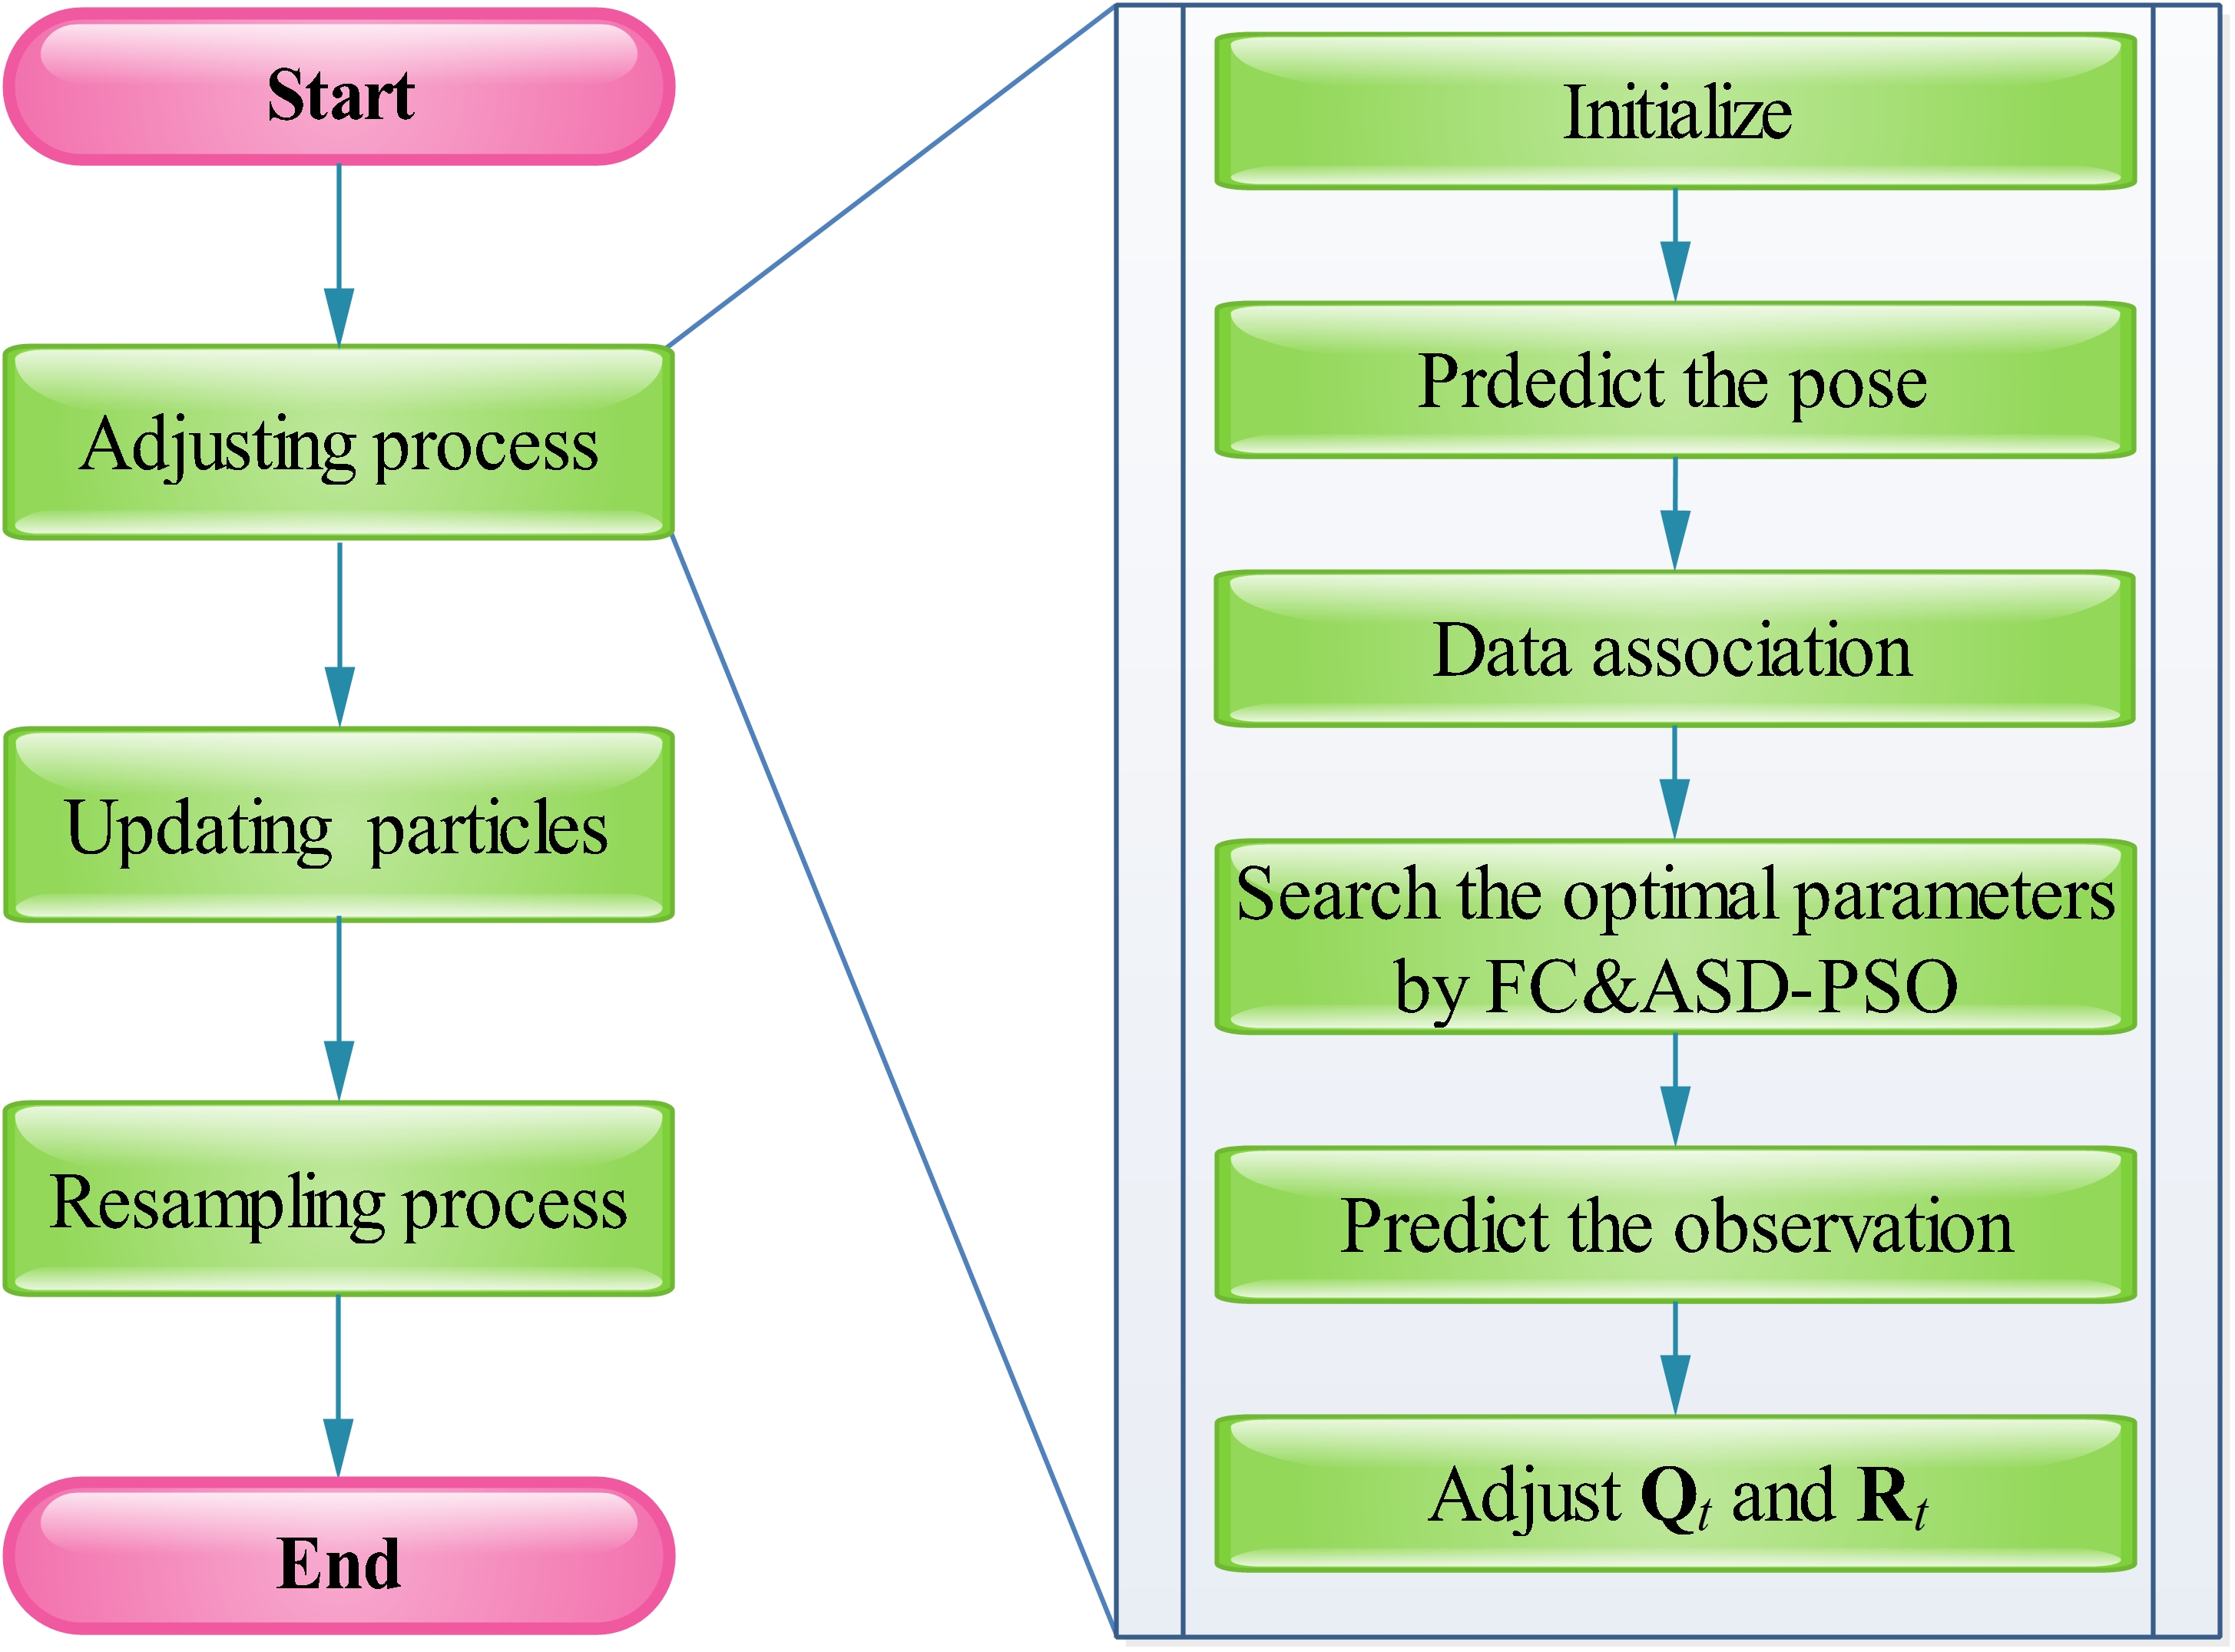
Image
1.3 MB
Lv and Feng supplementary material
Figure 5
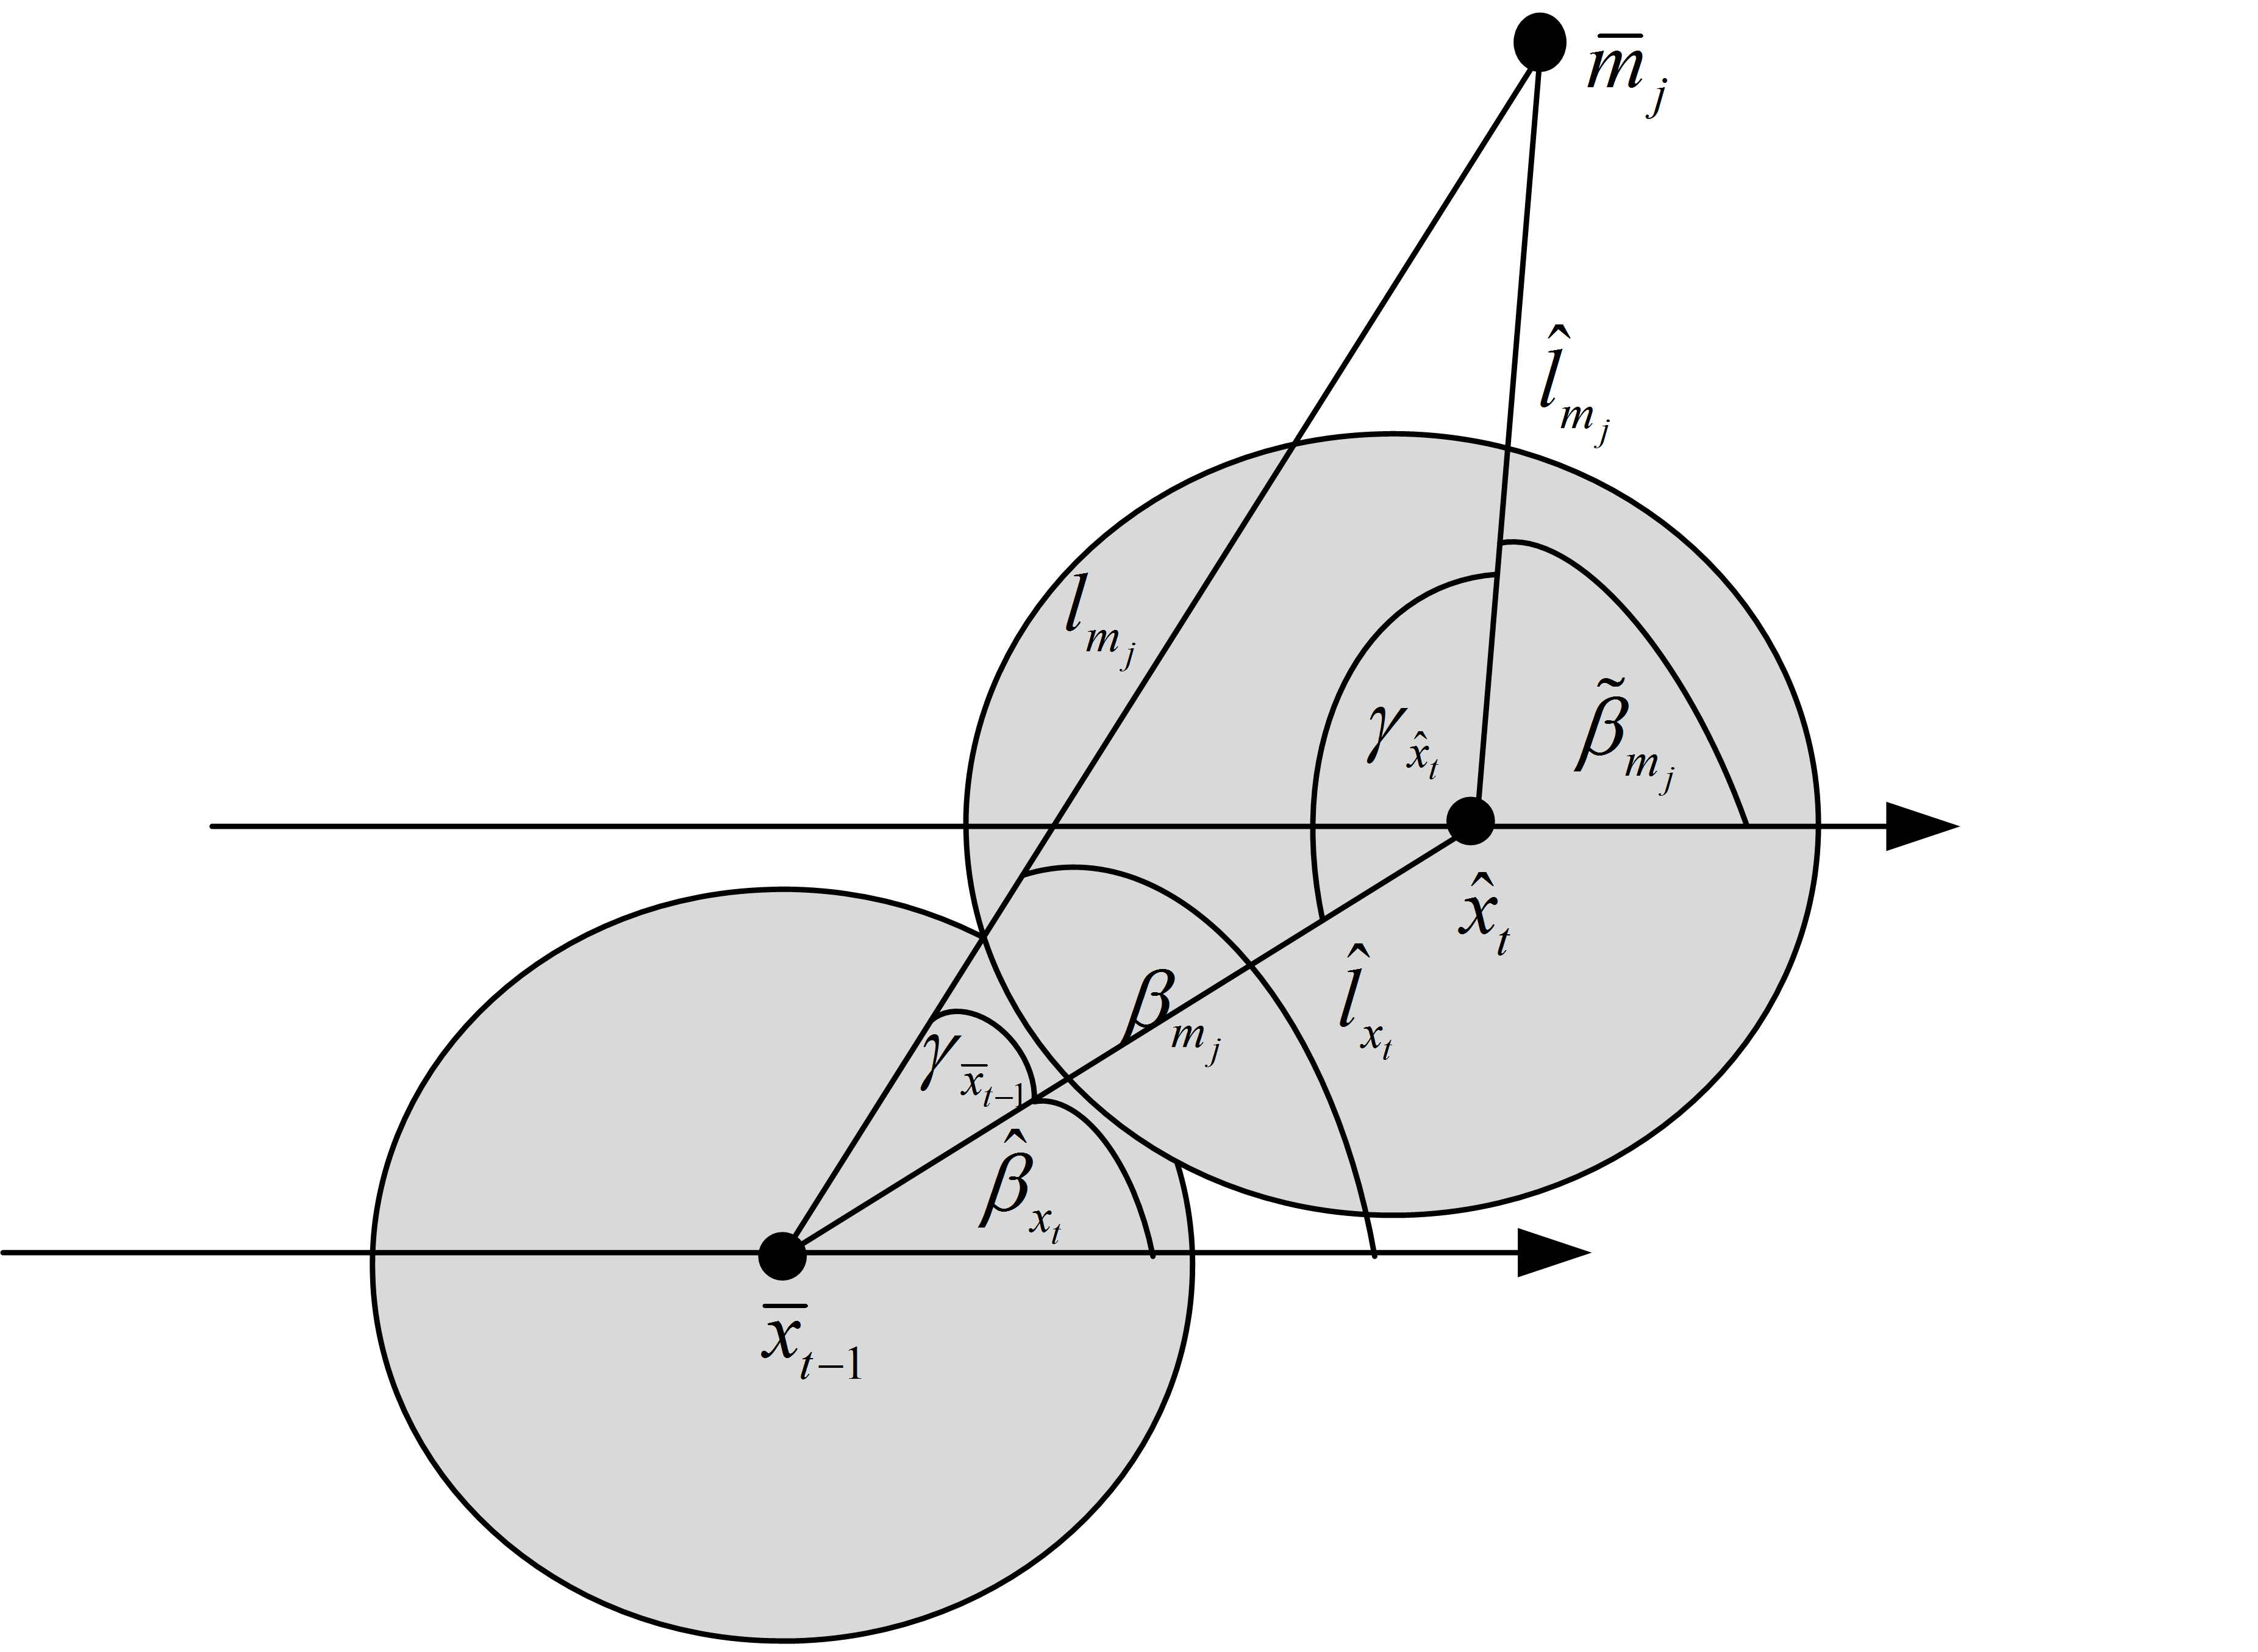
Image
312.6 KB
Lv and Feng supplementary material
Figure 6
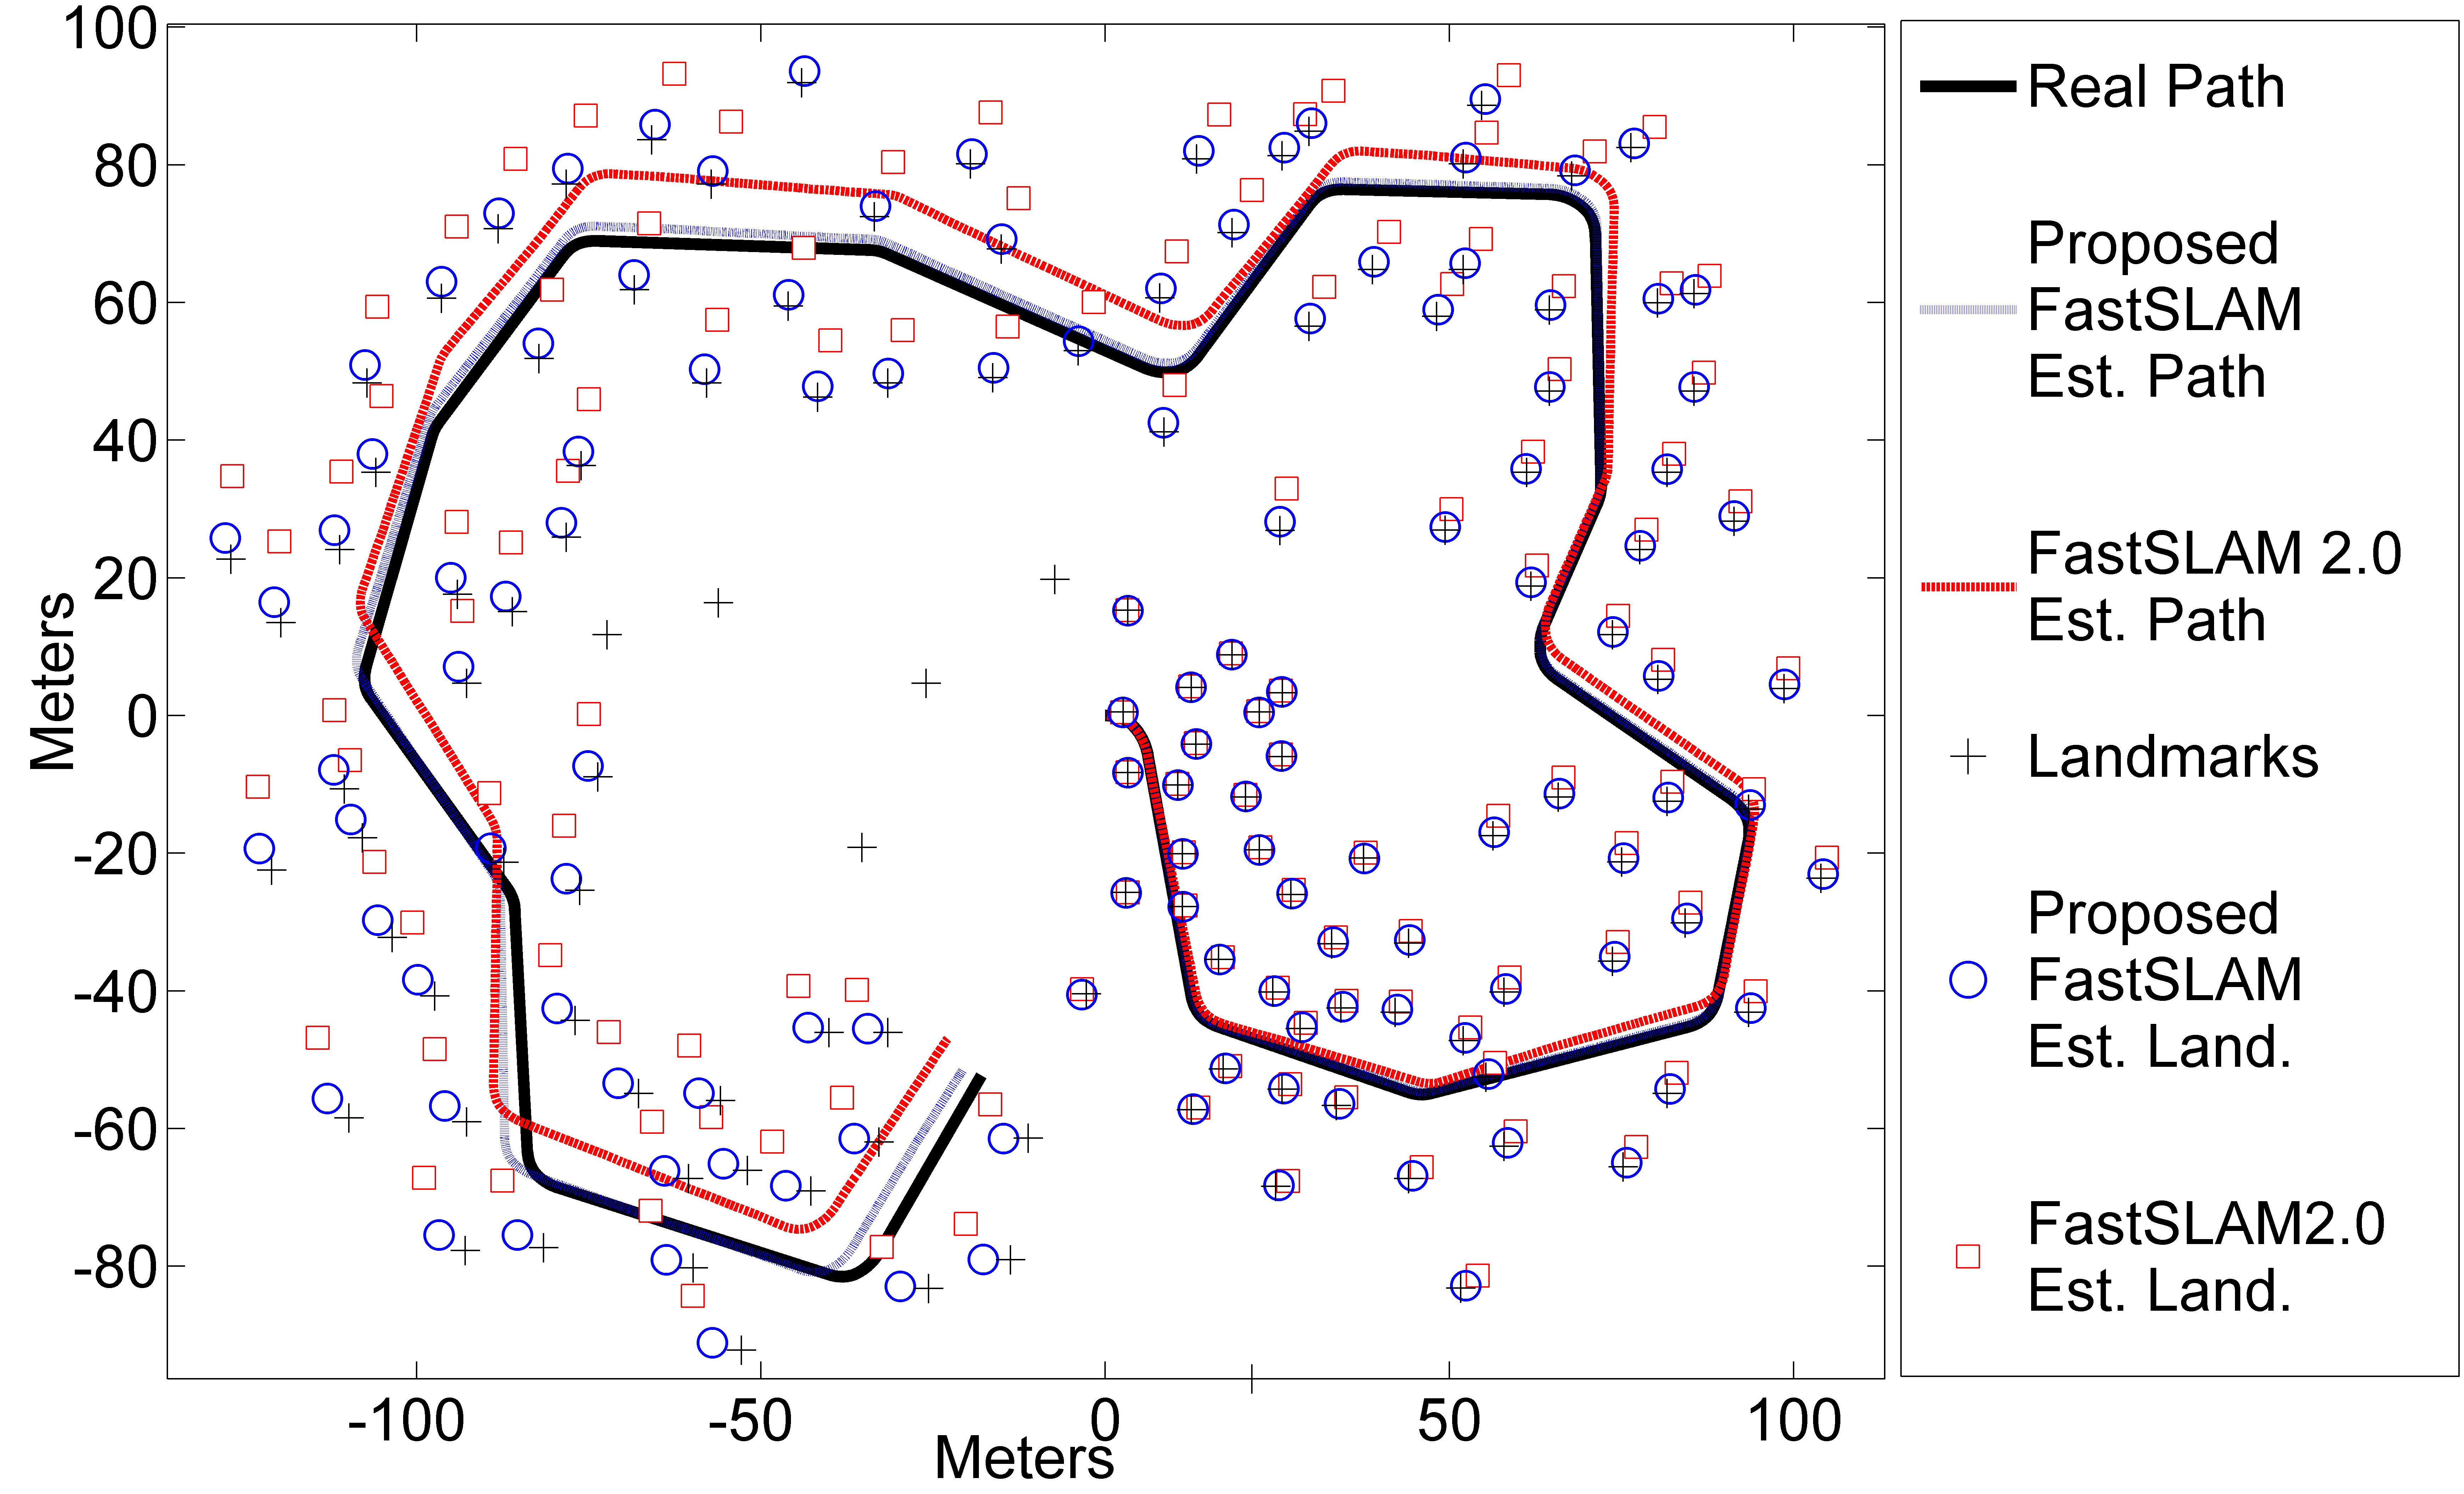
Image
5 MB
Lv and Feng supplementary material
Figure 7
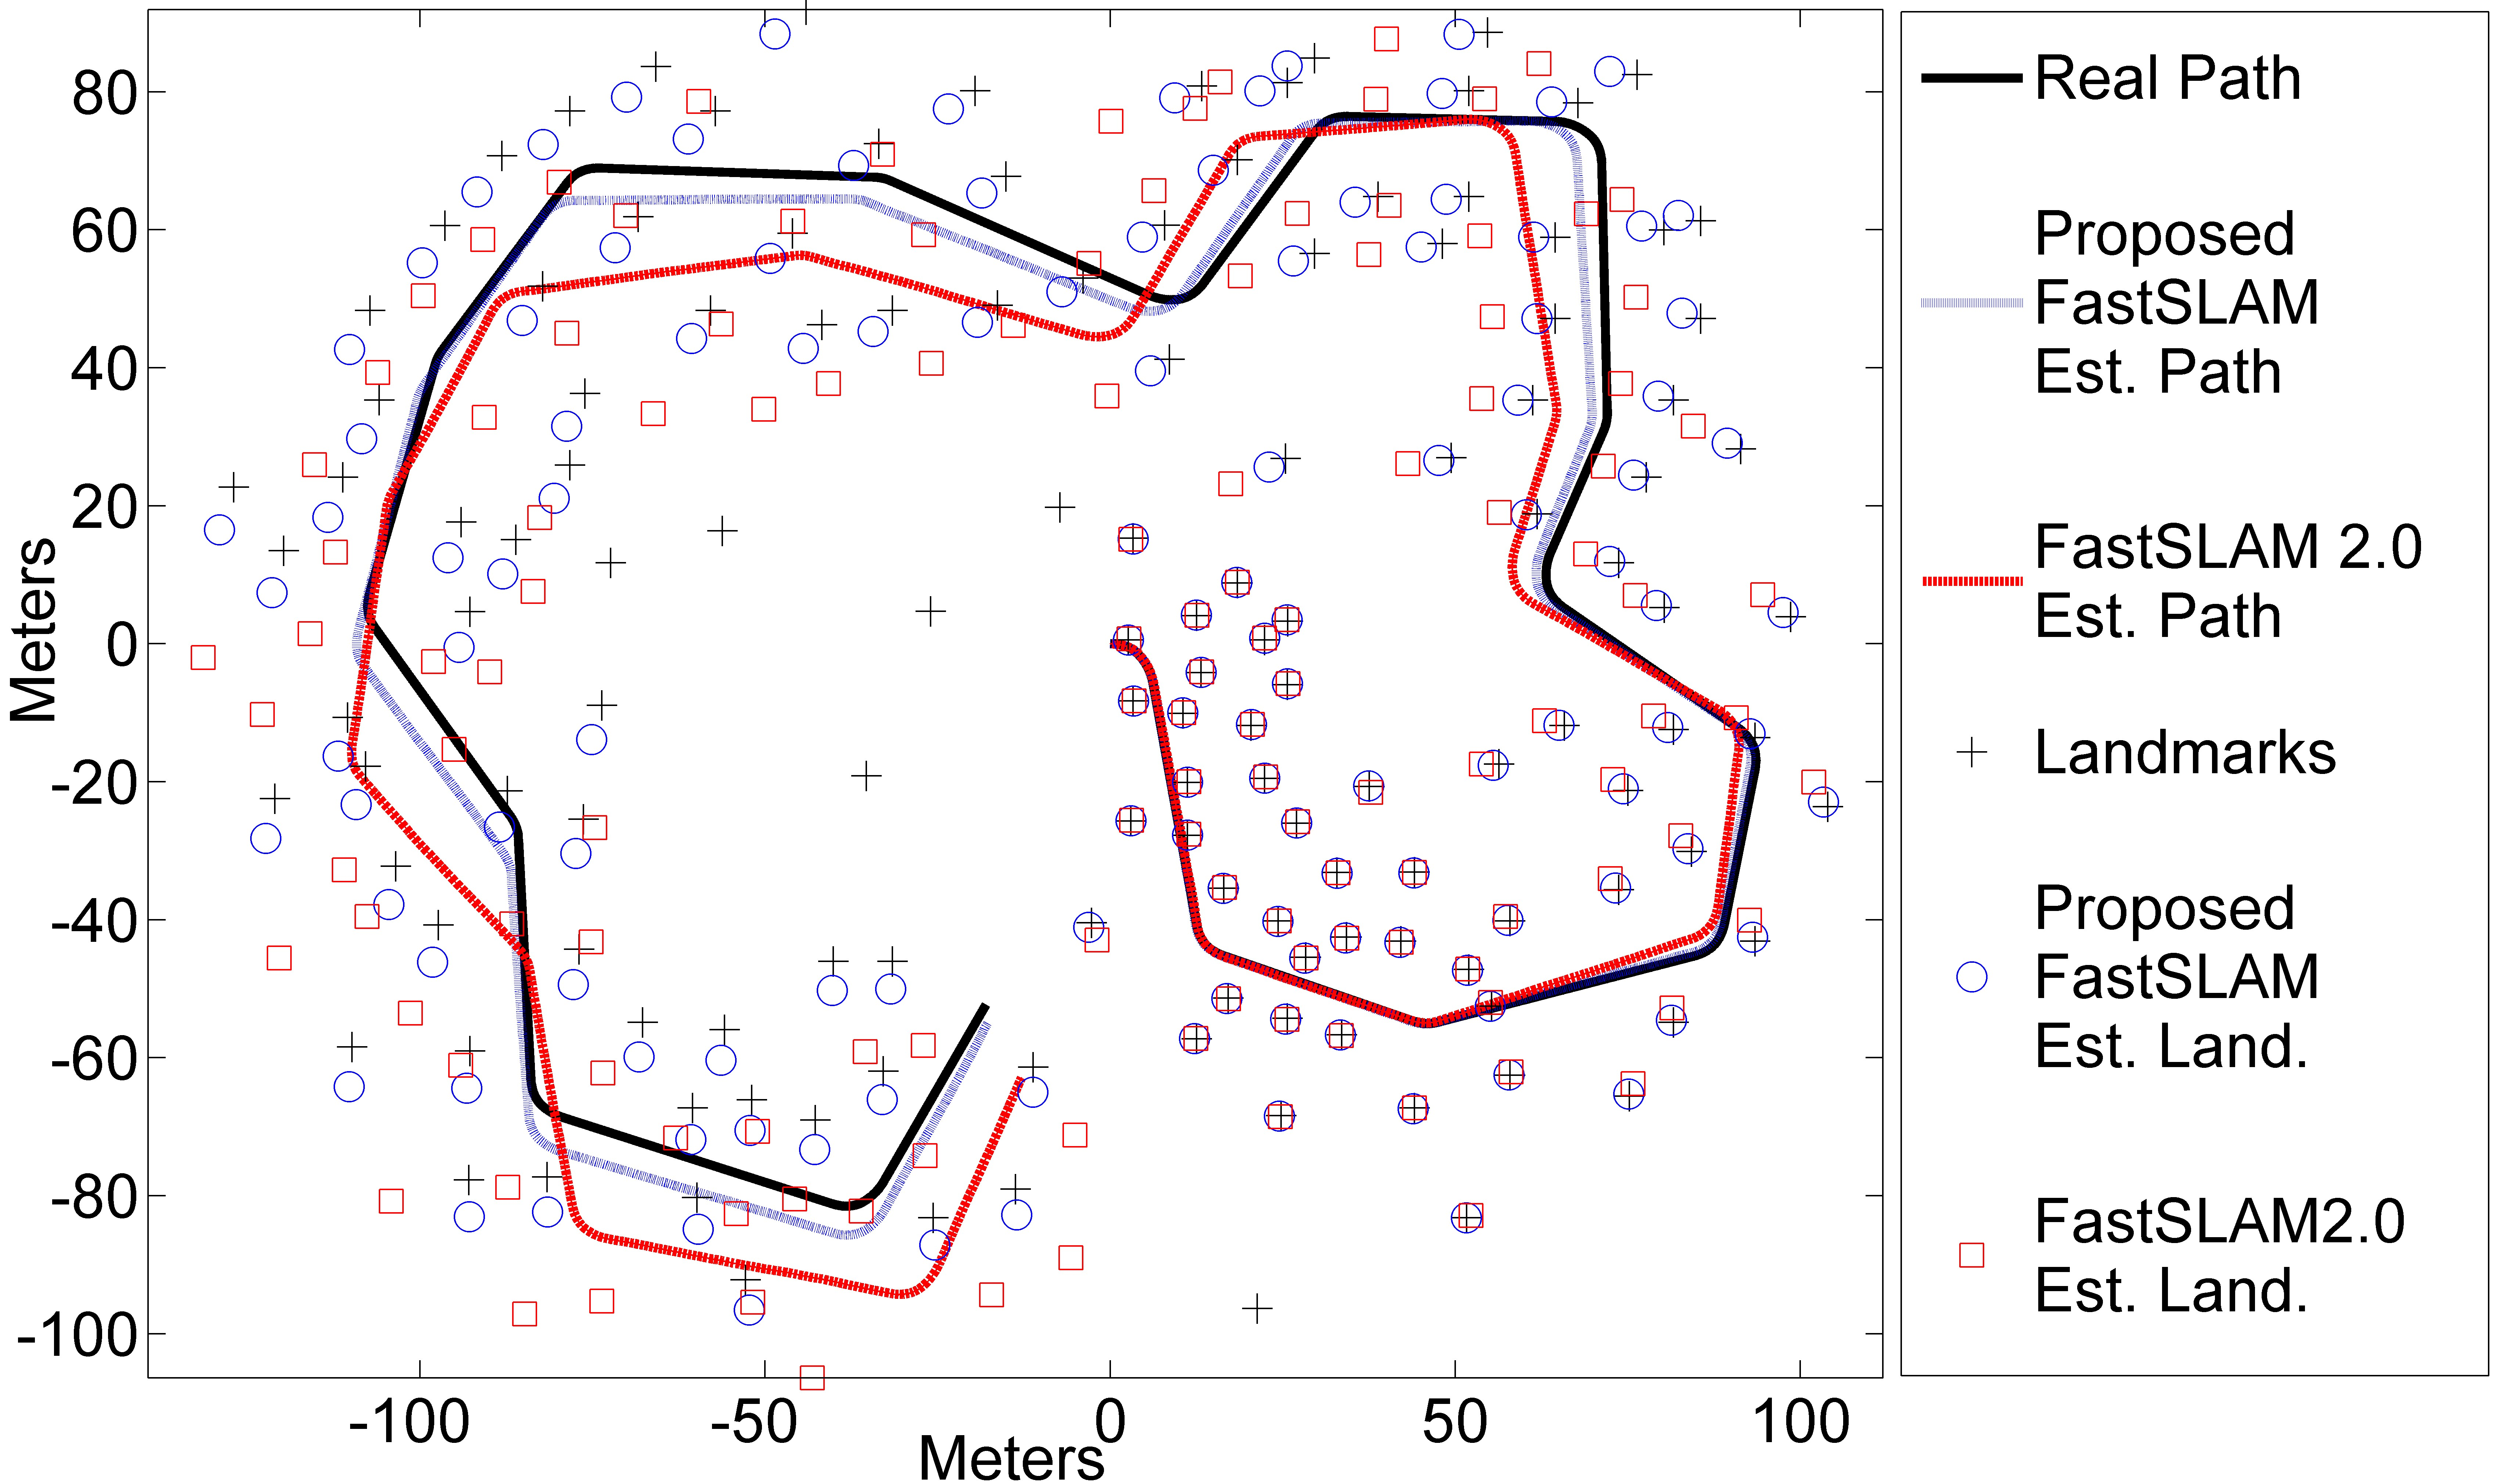
Image
4.7 MB
Lv and Feng supplementary material
Figure 8
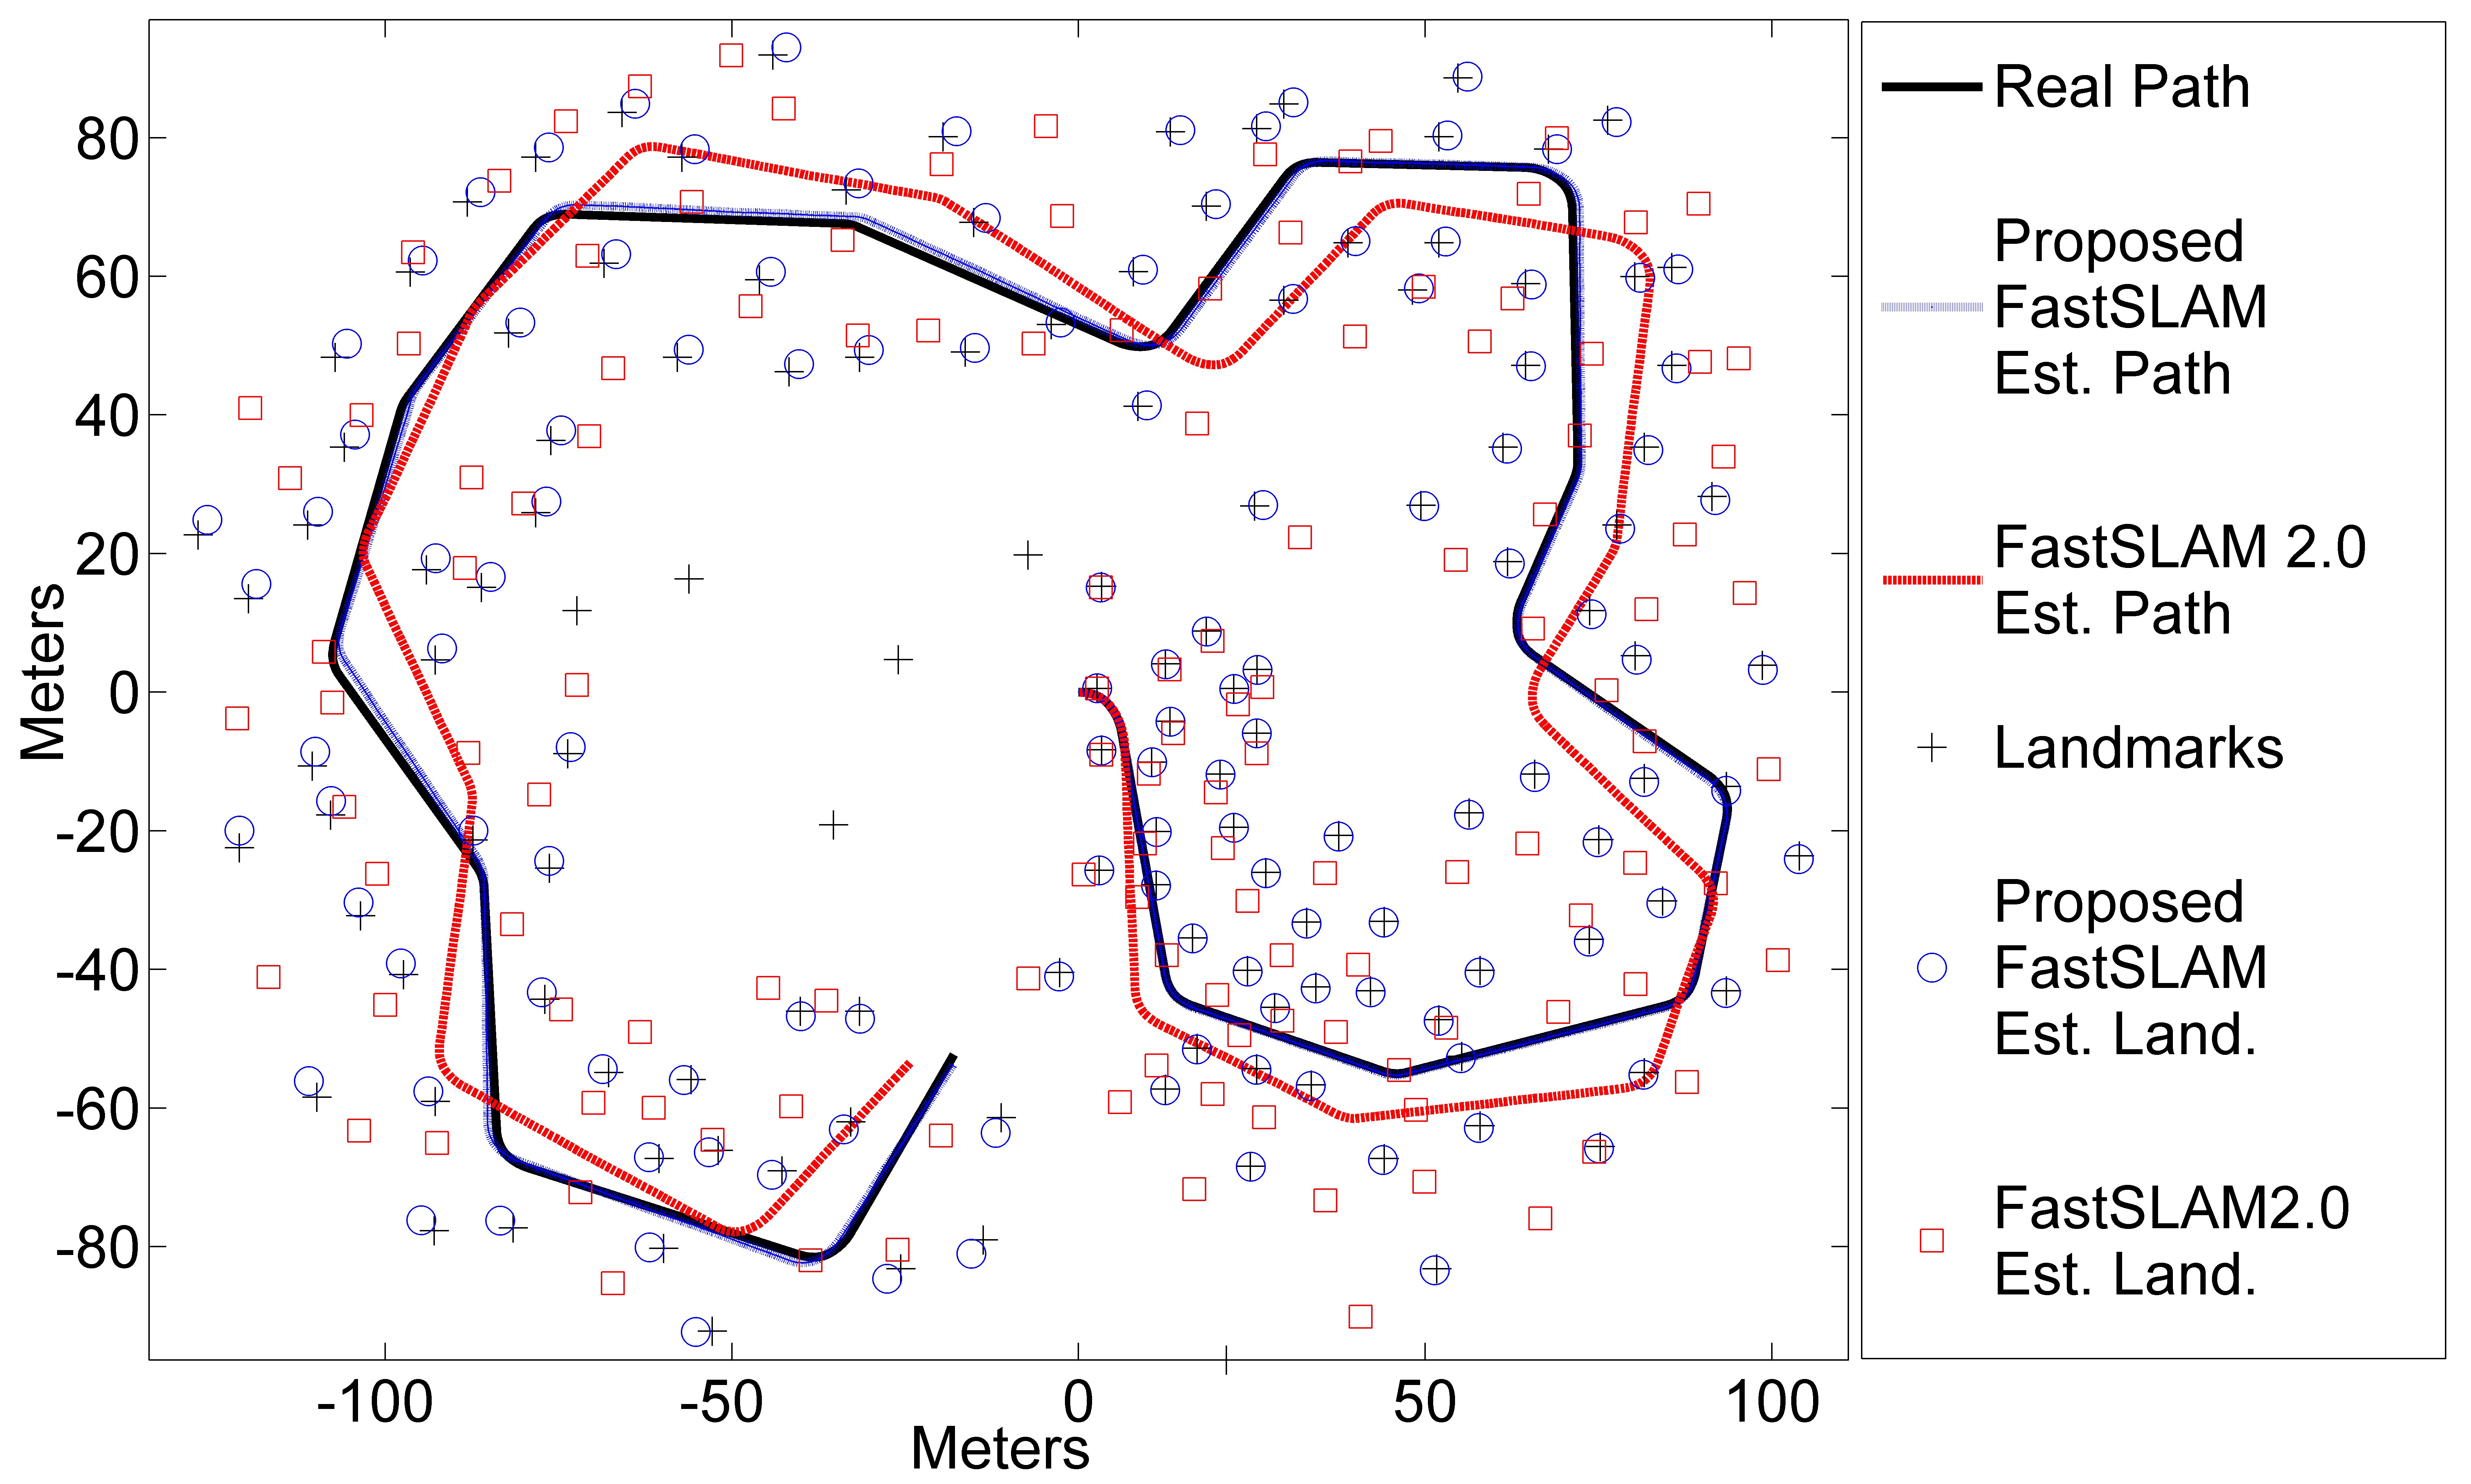
Image
5 MB
Lv and Feng supplementary material
Figure 9
Image
124.5 KB
Lv and Feng supplementary material
Figure 10
Image
44.6 KB
Lv and Feng supplementary material
Figure 11
Image
121.4 KB
Lv and Feng supplementary material
Figure 12
Image
38 KB
Lv and Feng supplementary material
Figure 13
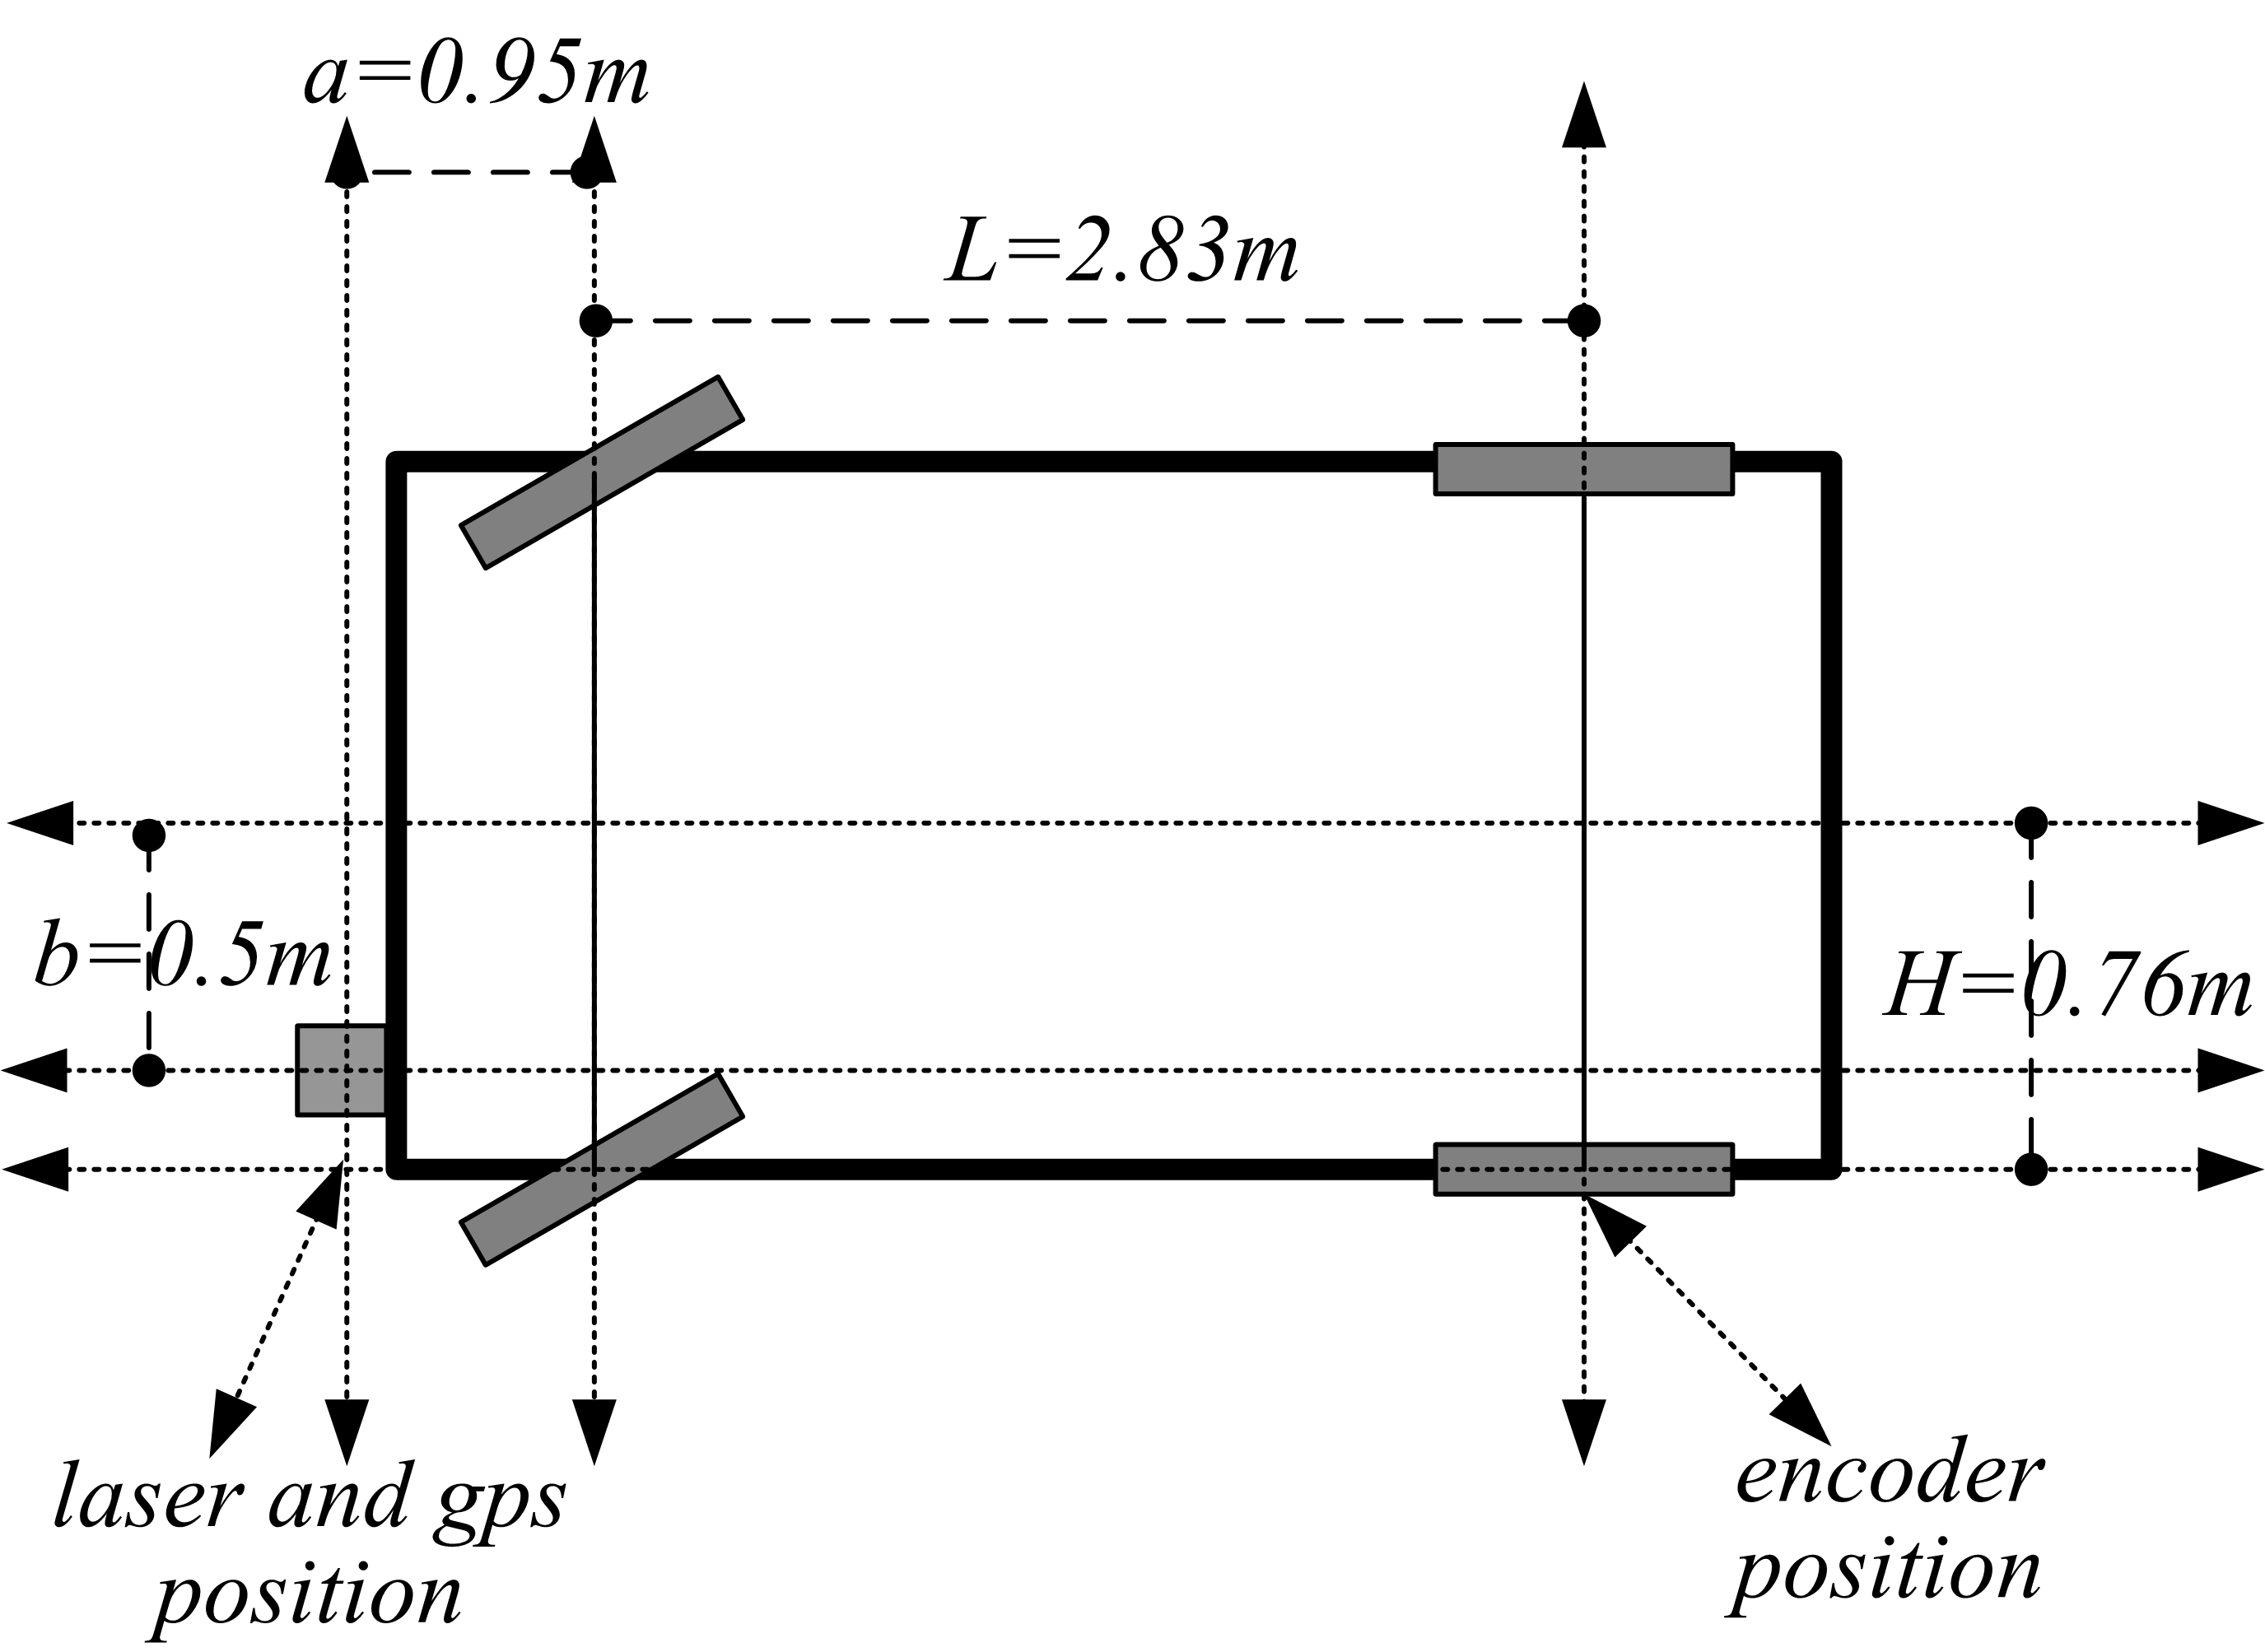
Image
213.6 KB
Lv and Feng supplementary material
Figure 14
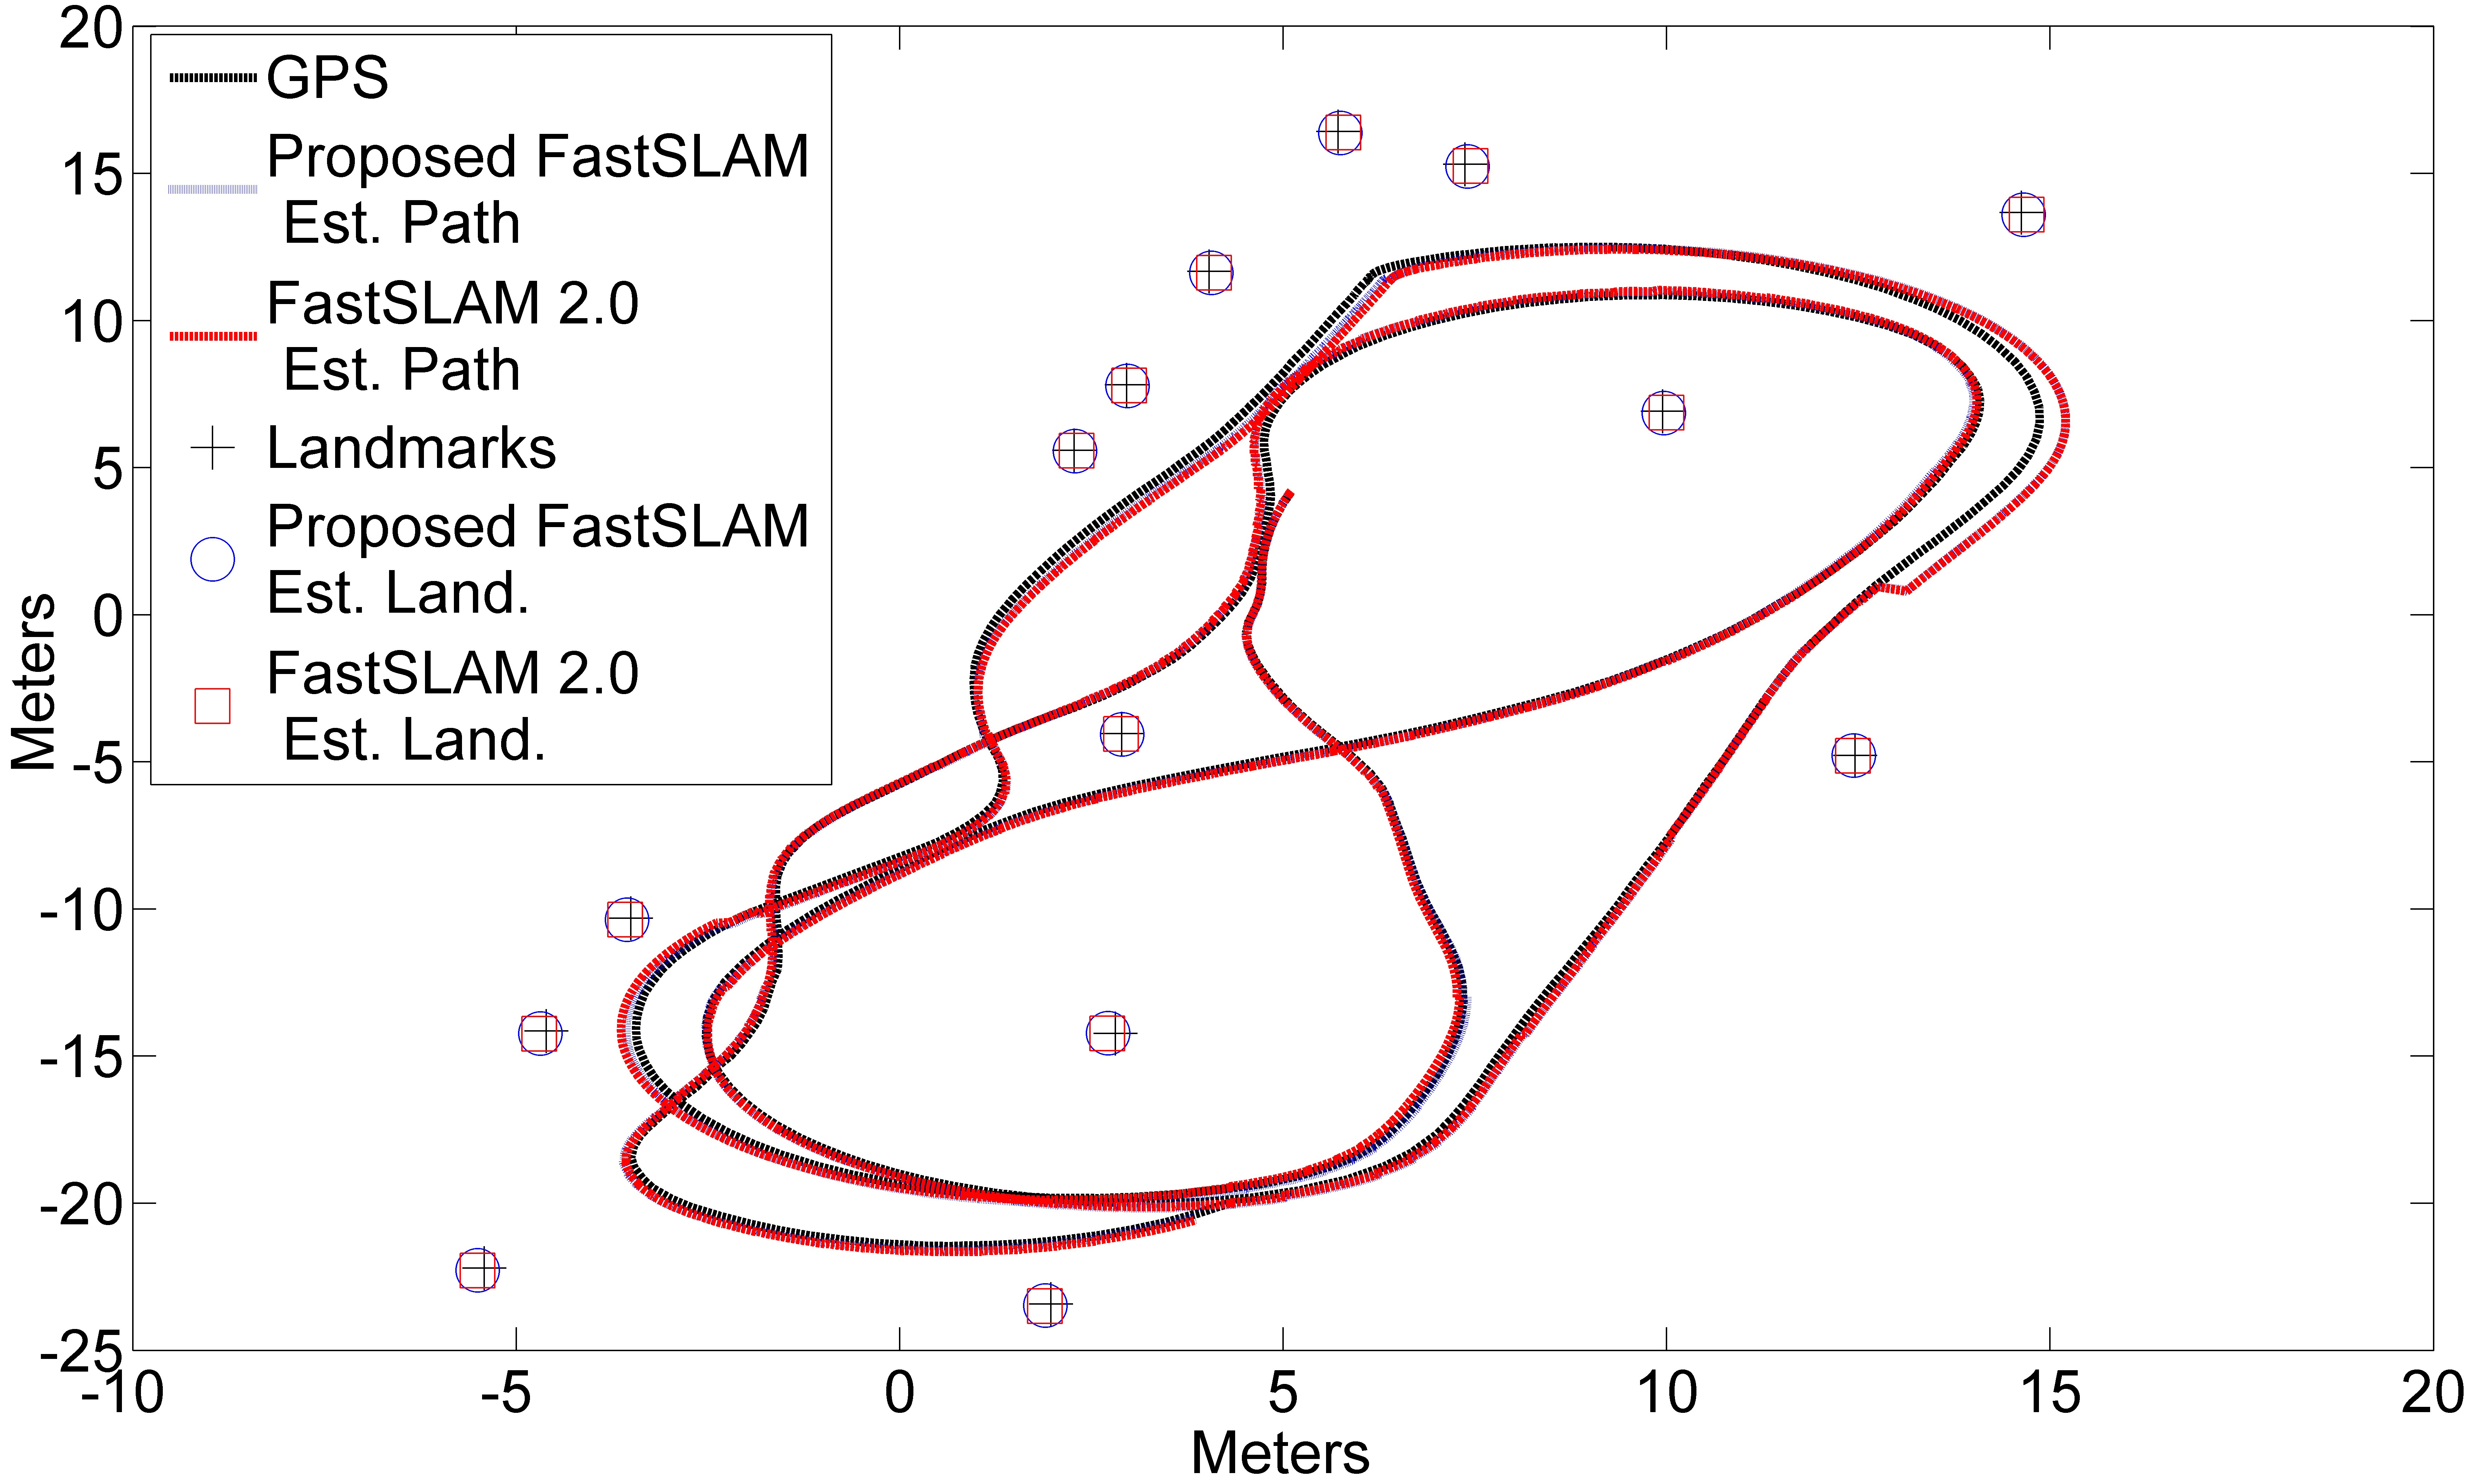
Image
3.9 MB
Lv and Feng supplementary material
Figure 15
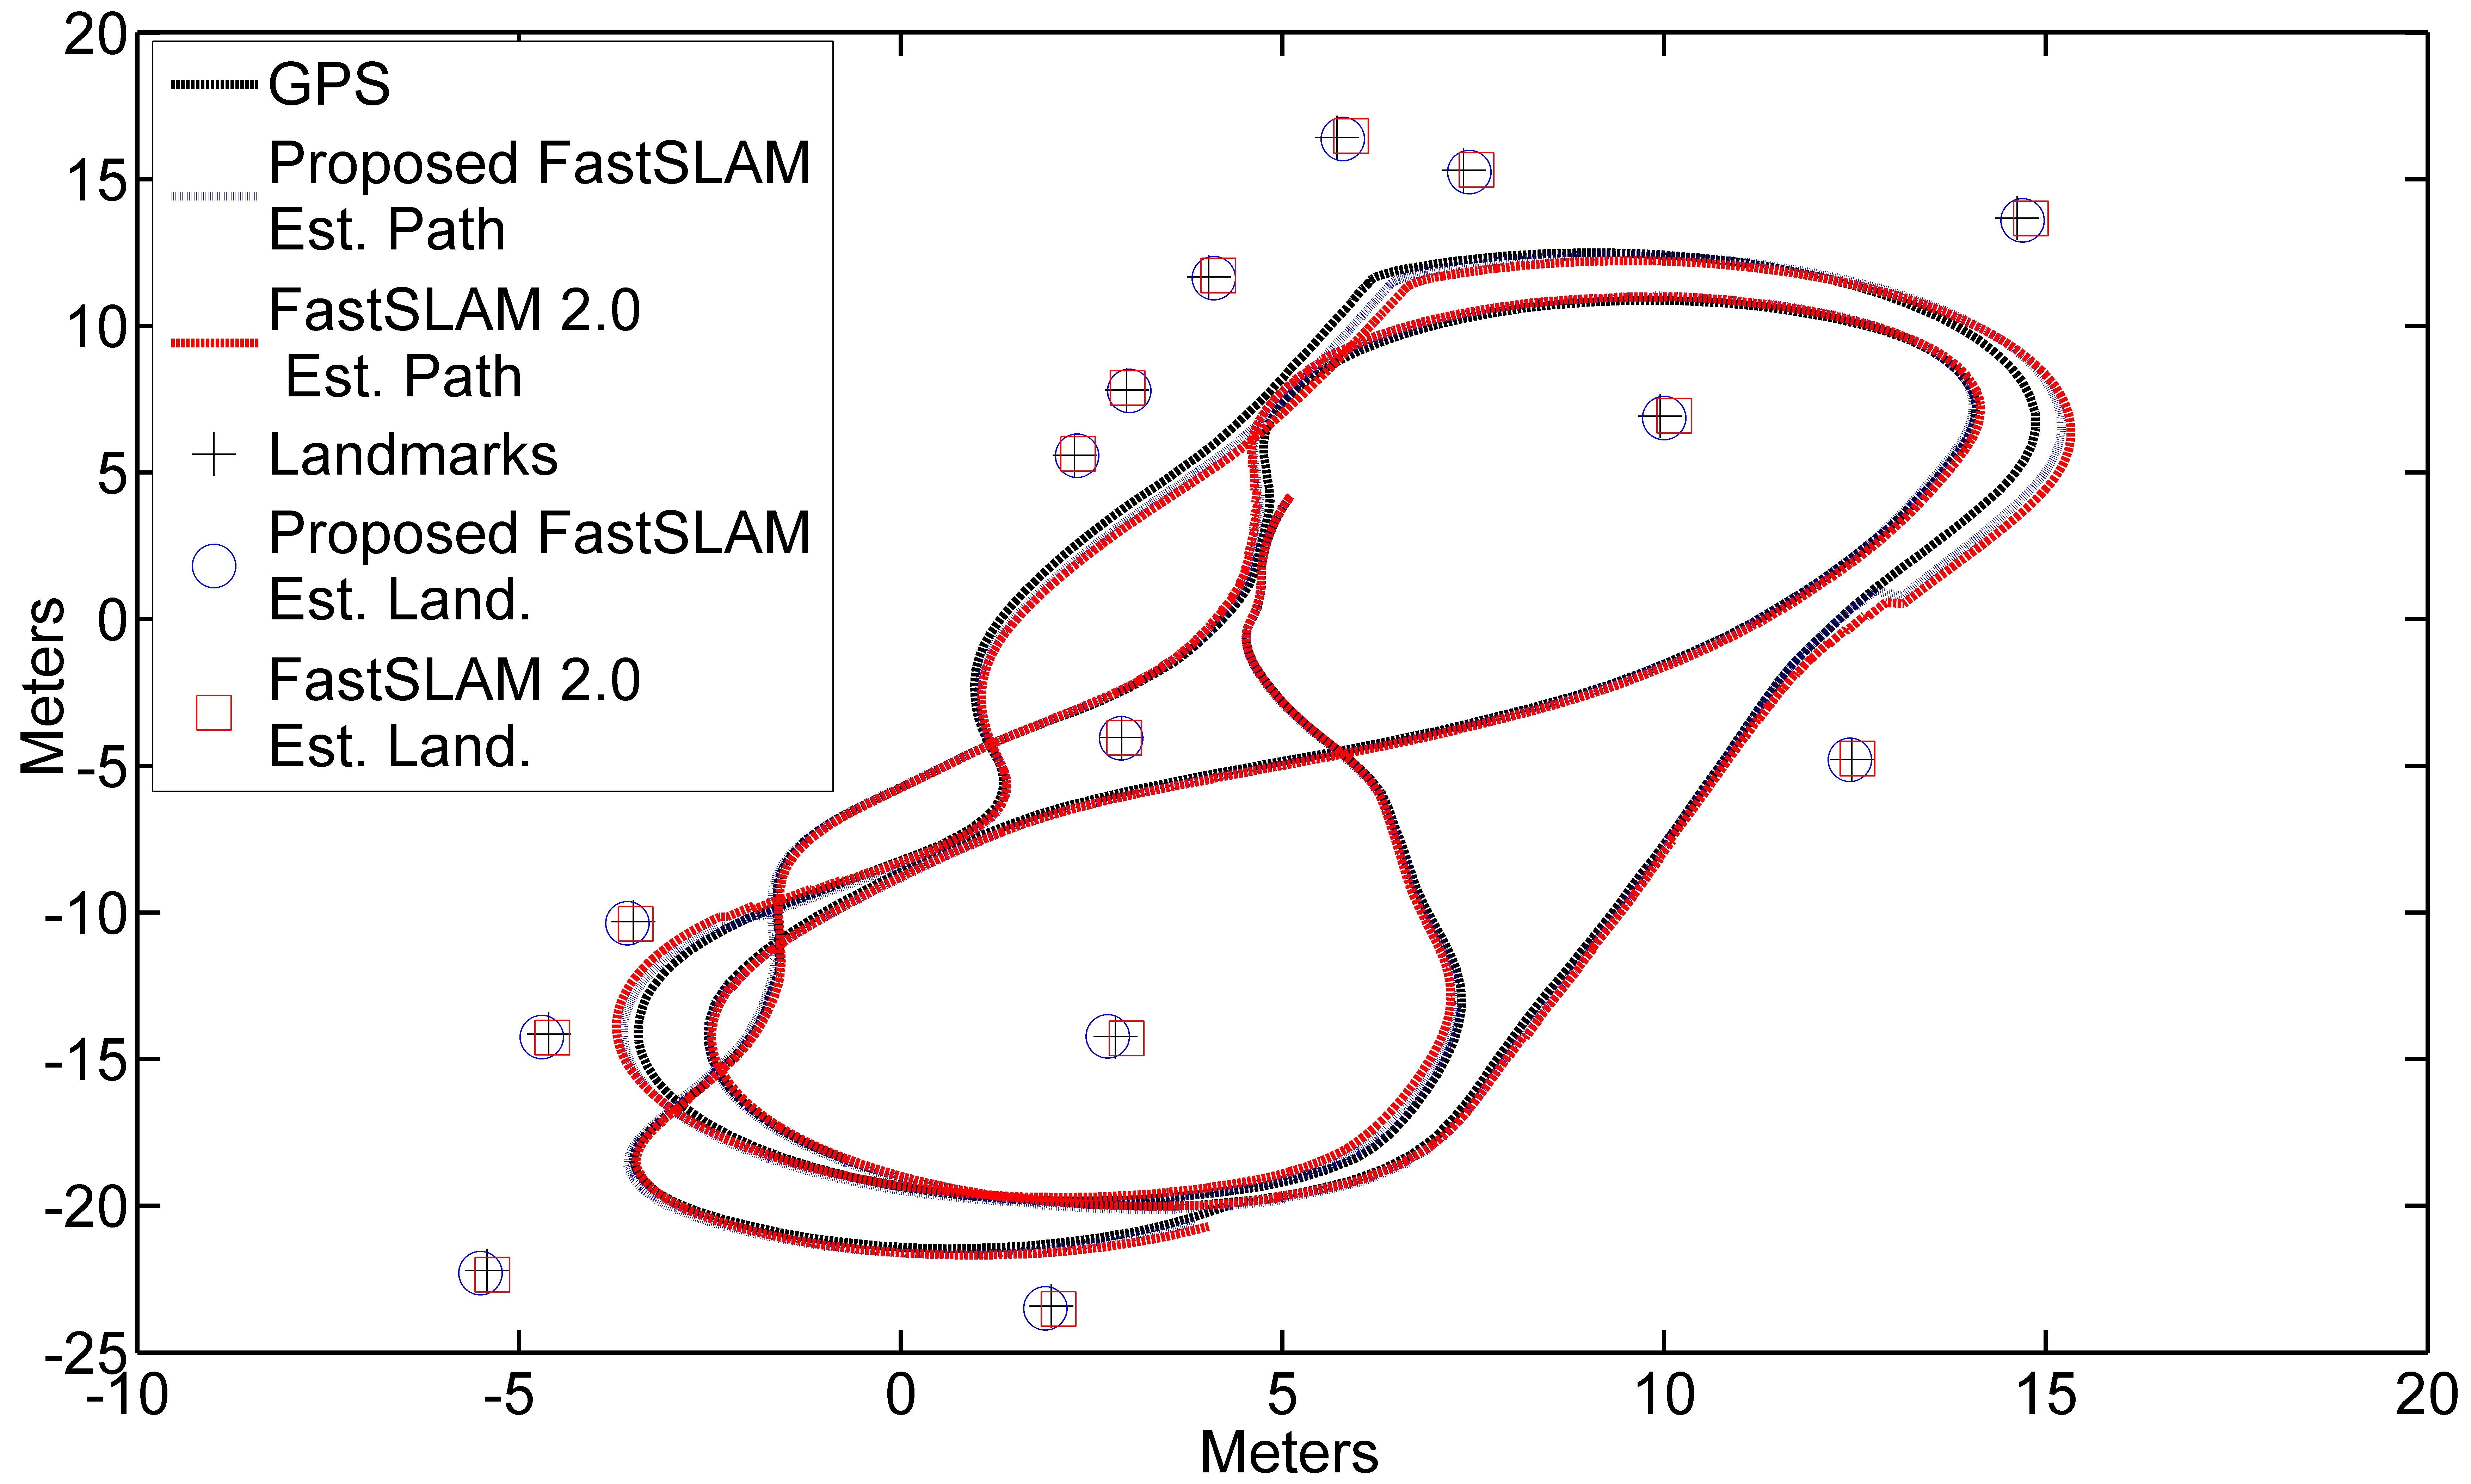
Image
4.2 MB
 You have
Access
- 7
- Cited by