


1. INTRODUCTION
The broad theme of reliability theory is the study of the overall performance of a system comprising failure-prone elements (components). In addition to the problem of determining the reliability function of a system, whose components are subject to failure, ample research effort has been spent in the statistical engineering and operations research literature and in the introduction and investigation of several aging concepts either at the component or system level. Historically, aging has first been conveniently expressed in terms of the failure rate function. In the simplest case, when no aging is present, we have a constant failure rate, corresponding to the exponential distribution. A very broad class that includes many of the most common distributions and has received considerable attention is the class of distributions exhibiting a monotonically increasing failure rate (IFR distributions). Membership in the class confers a number of interesting and important properties that can be effectively used for understanding system's performance. For example, once we know that a system has an IFR, we can obtain moment inequalities and bounds for the structure's lifetime, we can easily establish the optimum policy in certain planned replacement models, and so forth. For a review of early techniques on this subject we refer to the classical book by Barlow and Proschan [1] and the publication of Esary and Proschan [5].
Unfortunately, the formation of a coherent system of independent IFR components does not necessarily yield an IFR system lifetime. Therefore, even if we use IFR components, we cannot take advantage of the properties conferred by the IFR family at the system's level unless appropriate conditions certify that the property is carried over to the whole structure. In the light of this evidence, it would be valuable to develop simple sufficient conditions under which a system of components each having the IFR aging property has an IFR lifetime as well.
In this article we confine ourselves to a class of reliability structures that can be efficiently described through finite Markov chains (see Koutras [8]). As stated in [8], in many engineering systems it is feasible to study their reliability characteristics by replacing the 2n possible component states by N < 2n states and subsequently using a proper Markov chain to capture the reliability function. When N is small compared to 2n, this approach provides an efficient tool not only for the system's reliability evaluation but also for the study of other properties of the structure, such as its asymptotic behavior, generating function, development of reliability bounds, optimal arrangement problems.
One of the earliest works in this direction was published by Fu [6]. Later, in a series of articles by Chao and Fu [3,4] and Fu and Lou [7], the method was successfully applied in the study of the k-out-of-n, consecutive-k-out-of-n, and certain repairable systems. All of these systems (named linearly connected systems by Fu and Lou [7]) were first imbedded into a nonhomogeneous Markov chain, defined on a finite state space with an absorbing state and subsequently analyzed by examining the ergodicity of the transition probability matrix product. Recently, Koutras [8] suggested a unified framework for analyzing reliability structures that can be described by finite Markov chains. The formal definition of such structures, which have been termed Markov chain Imbeddable Systems (MISs), is given in Section 2 along with all necessary notations, definitions, and preliminary material. In Section 3 a sufficient condition is given for the lifetime of an MIS to have an IFR when the identical and independent components comprising it own this property. In Section 4 we consider the family of k-out-of-n:F systems, and exploiting the general approach described in Section 3, we present a new proof of the IFR closure property for this specific class of reliability systems. This is actually equivalent to the well-known result that the order statistics of independent and identically distributed (i.i.d.) IFR random variables hold the IFR property as well. Finally, we illustrate how the approach taken here can be applied to a generalization of the k-out-of-n:F systems: the weighted k-out-of-n:F systems.
2. PRELIMINARIES AND NOTATIONS
Consider a reliability system consisting of independent components. At a specific instance, each component is either operational (working, up, on) or failed (down, off). The state of the system (operational/failed) is completely determined by the state of its elements, this dependence being reflected at the value of the so-called structure function. To set up our mathematical notation, denote by I the set of components of the structure and introduce, for each component α ∈ I, a binary random variable Xa indicating whether the component is up (Xa = 1) or down (Xa = 0). Then the state of the system will be described by the value of the structure function φ = φ(Xa,α ∈ I) (φ = 1 if the system is up and φ = 0 if the system is down). An alternative way to describe a coherent reliability structure is by providing system's minimal cut sets (C ⊆ I is a cut set if the failure of all components α ∈ C results in the system's breakdown).
As stated in Section 1, the present article focuses on a wide class of reliability structures whose failure can be efficiently described by absorbing states of finite Markov chains. The formal definition of these structures is as follows (see also Boutsikas and Koutras [2]).
Definition 2.1: A sequence of coherent structures with set of components Jn and respective family of minimal cut sets Cn,n = 0,1,2,…, will be called a Markov chain imbeddable sequence if the following hold:
(a) Jn ⊆ Jn+1, and Cn ⊆ Cn+1, for n = 0,1,2,….
(b) There exists a Markov chain {Yn,n = 0,1,…} defined on a finite state space S = {s0,s1,…, sN}, with the following property: Yn = sN if and only if the nth system of the sequence fails [i.e., ΠC∈Cn(1 − Πi∈C(1 − Xi)) = 0].
The members of a Markov chain imbeddable sequence will be called Markov chain imbeddable systems (MISs).
The above definition is in compliance with the one given by Koutras [8] and can accommodate the structures studied by Chao and Fu [3,4] and Fu and Lou [7].
It is clear, by condition (a) of Definition 2.1 that state sN is an absorbing state for the Markov chain {Yn,n = 0,1,…}.
Let us next denote by

the transition probability matrix of the Markov chain and by

the vector of initial probabilities. Then the reliability function of the nth MIS can be expressed as (cf. Koutras [8])

In the sequel, we will confine ourselves to the special case in which the transition probabilities P(Yn = sj|Yn−1 = si) do not depend on n; that is, P(Yn = sj|Yn−1 = si) = pij for all i,j = 0,1,…, n and Λn = Λ1 for all n = 1,2,… (homogeneous Markov chain imbeddable sequence or simply homogeneous MIS). This is usually the case when the components of the system are identical and work independently (i.i.d. system). Denoting by p the common survival probability of the components, the system's reliability hn will be a function of p; that is,

Since state sN is an absorbing state, the transition probability matrices Λn = Λ1, n = 1,2,… can be decomposed as

where Λ is an N × N square matrix and

are column vectors. The nth power of Λn = Λ1 now reads (see, e.g., Taylor and Karlin [11])

and substituting in formula (2.1), we arrive at the alternative expression

where

N consists of the first N entries of π0 and

. An assumption that will be taken for granted hereafter without explicitly mentioning it is that hn(p) is not constant for n = 1,2,….
3. THE IFR PROPERTY PRESERVATION FOR MARKOV CHAIN IMBEDDABLE SYSTEMS
In this section we assume that the structure consists of i.i.d. components. For computational convenience, let us assume that Ji = {1,2,…, i} and denote by I = Jn = {1,2,…, n} the set of nth system's components. If at a given instance t each component has survival probability p = p(t), then the reliability of the nth system can be expressed as

The common failure rate r(t) of the n components is given by

whereas the system's failure rate is given by

Esary and Proschan [5] established a very interesting formula connecting rS(t) and r(t), which proved to be instrumental in the development of our results. More specifically, they proved that

where

Expression (3.1) induces a simple sufficient condition on system structure that will preserve a monotone failure rate when the system is constructed out of independent alike components. More specifically, it is straightforward to verify the following:
(a) If r(t) is an increasing function of t and g(p) is a decreasing function of p, then rS(t) is an increasing function of t.
(b) If all of the components have a constant failure rate (i.e., their lifetime distribution is exponential), then the system's failure rate rS(t) has as many changes as a function of t as does g(p) as a function of p, these changes occurring in the opposite order. Therefore, if g is decreasing, then rS(t) is increasing (the system owns the IFR property), whereas if g is increasing, then rS(t) is decreasing (the system owns the decreasing failure rate (DFR) property).
On the basis of the above-mentioned points, the behavior of g as a function of p can determine the IFR property preservation from the component level to the system level. In the sequel we will provide sufficient conditions guaranteeing the monotonicity of g when the system under investigation belongs to the MIS family.
Note first that the transition probabilities

take on values from the set {0,p,1 − p}; that is, the nonvanishing entries of the matrix

are either p or 1 − p. Therefore, the entrywise derivative of Λ(p)

will contain only three types of element (0, 1, or −1) and does not depend on p.
In order to investigate the monotonicity of g(p) (cf. (3.2)), it is essential to develop a neat expression for

The first step toward this direction is achieved by the following proposition
Proposition 3.1: If there exists c ∈ R such that

then

Proof: We will first prove that under assumption (3.3), the following identity holds true for all n = 1,2,…:

Our assertion is apparent for n = 1. Assume next that the identity is true for n = k; that is,

Then applying the product rule of the matrix entrywise differentiation (cf. Lutkepohl [9])
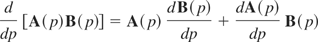
for A(p) = Λk(p) and B(p) = Λ(p), we can write

Replacing dΛk(p)/dp by virtue of (3.5) and making use of (3.3), we get

Hence, (3.4) holds true for n = k + 1. Consequently, by the induction principle, we conclude that (3.4) is valid for all n = 1,2,…
The desired result is now easily obtained by a direct substitution of (3.4) in the expression

It is worth mentioning that in the case c = 1 (i.e., when ΛΛ′ = Λ′Λ), hn′(p) takes on the more familiar form

A wide class of MISs in which the previous formula can be applied is systems whose transition matrices Λ are upper diagonal, with all elements in the same diagonal being equal. This is ascertained by the following proposition.
Proposition 3.2: Let A = [αij]m×m and B = [bij]m×m denote two upper triangular matrices with the elements in each diagonal being the same; that is, ai,i+s−1 = as and bi,i+s−1 = bs for i = 1,2,…, m and s = 1,2,…, m − i + 1. Then matrices A and B commute (i.e., AB = BA).
Proof: The proof follows immediately by simple algebraic calculations. █
It is clear that if Λ is upper diagonal with all elements in the same diagonal equal, Λ′ possess the same property, and applying Proposition 3.2 for A = Λ and B = Λ′, we conclude that Λ and Λ′ commute.
Before stating our main result on the monotonicity of g(p) and the IFR property preservation under the formation of MISs, we need some additional notation. Let

be the set of states from which a one-step transition to the absorbing state is feasible and

the set of states from which the absorbing state is not accessible directly. Manifestly, the state space S is now partitioned into three subsets as follows:

Moreover, let us introduce the notation

for the probabilities that the Markov chain is visiting (at time n) the states of A and B, respectively.
We are now ready to state the main result of this section.
Proposition 3.3: Consider a Markov chain imbeddable sequence such that condition (3.3) holds true. If the quantity

is an increasing function of p, then the nth member of the family preserves the IFR property.
Proof: Let a = (a0,a1,…, aN−1)′ be the vector indicator of A; that is,

(note that the absorbing state sN has been excluded from the vector). It is straightforward to verify that Λ1 = 1 − qa = 1 − (1 − p)a and, consequently, Λ′1 = a. Hence, the reliability function hn(p) can be expressed as

whereas hn′(p), in view of Proposition 3.1, takes on the form

In view of the last two expressions, (3.2) yields

which can be equivalently written in the form

Observe next that 1 − a = b is the indicator vector of B and

Therefore,

and the conclusion stated in the proposition is now obvious. █
If we use the notation

we can express Rn(B)(p) as

and the next corollary follows readily from Proposition 3.3.
Corollary 3.1: Consider a Markov chain imbeddable sequence such that condition (3.3) holds true. If the quantities

are increasing functions of p for all j ∈ B, then the nth member of the family preserves the IFR property.
4. AN APPLICATION TO THE k-OUT-OF-n SYSTEM
An illustrative example of application of the methodology presented in the previous section is offered by the k-out-of-n:F system. This structure fails if at least k components fail to work. It is clear that the lifetimes of the k-out-of-n:F systems coincide with the order statistics of the random variables describing the components' lifetimes. Therefore, proving the IFR closure property for this specific class of reliability systems is in fact equivalent to the well-known result that the order statistics of i.i.d. IFR random variables hold the IFR property as well.
An imbedding of the system is easily achieved by considering the state space S = {s0,s1,…, sk} (i.e., N = k) and the Markov chain {Yn,n ≥ 0} defined as follows:
- Yn = si if exactly i of the components 1,2,…, n are down (0 ≤ i < k).
- Yn = sk if at least k of the components 1,2,…, n are down.
Fu and Lou [7] (see also Koutras [8]) stated that the transition matrix is given by

where pn, n = 1,2,…, denotes the survival probability of the nth component, and used this setup to derive asymptotic results for large k-out-of-n:F systems. In the i.i.d. case (pn = p for n = 1,2,…), it is obvious that

where

The first derivative of matrix Λ is given by

and, therefore (cf. remark following Proposition 3.2), matrices Λ and Λ′ commute.
As a consequence, we can exploit Proposition 3.3 to study the IFR property preservation of the family of k-out-of-n systems. It is evident that

whereas for the quantities Rn(j)(p),j = 0,1,…, k − 1, we have

Hence,

and an obvious conclusion drawn from the last expression is that the quantity under investigation is an increasing function of p for all sj ∈ B (i.e., for j = 0,1,…, k − 2). A direct application of Corollary 3.1 reveals that the k-out-of-n:F system preserves the IFR property. It is worth mentioning that in the special case k = 1, which corresponds to a series system, set B is empty and, therefore, the condition required for the application of Corollary 3.1 is trivially fulfilled.
Esary and Proschan [5] have provided a completely different proof of the IFR closure property for k-out-of-n:F systems. More specifically, they exploited the well-known relation between the tail probability of the binomial distribution and the incomplete Beta ratio to arrive at the following integral expression for the function g(p) defined in (3.2):

which reveals that g is a decreasing function of p (a convenient reference for this approach is Ross [10]).
Finally, we will illustrate how the general approach presented in Section 3 can be applied to the weighted k-out-of-n:F systems introduced by Wu and Chen [12]. These systems comprise an extension of the ordinary k-out-of-n:F system obtained by assigning a positive integer weight wi to each of the system components. Then, the system's breakdown occurs if and only if the total weight of failed components becomes at least k.
In order to imbed the system to a Markov chain, we can again consider the state space S = {s0,s1,…, sk} (i.e., N = k) and define {Yn,n ≥ 0} as follows:
- Yn = si if the total weight of the components 1,2,…, n that are down is exactly i (0 ≤ i < k).
- Yn = sk if the total weight of the components 1,2,…, n that are down is at least k.
In the case of i.i.d. components with survival probabilities pn = p,n = 1,2,…, the transition probability matrix associated with the nth component takes on the form (see Koutras [8])

where

and the system's reliability can be computed with the aid of the formula

It should be stressed that, in view of Proposition 3.2., matrices Mi and Mj commute for every i ≠ j and, therefore, the multiplication of matrices M1,M2,…,Mn can be performed in any order. In the sequel we will investigate two special cases of weighted k-out-of-n systems. In the first, we will prove that the IFR property is preserved. However, the second case illustrates a case in which the property is not preserved.
Let us consider first the special case of a weighted k-out-of-2n:F system with k = 6 and component weights

Then, the reliability of the system can be written as hn(p) = π′(M1M2)n1 = π′Λn1, where Λ = M1M2 and M1 and M2 are the following k × k matrices:

Note that the minimal cut sets of this system are not all of the same size (as it happens for the ordinary k-out-of-n system). More specifically, we have now two types of cut set: cut sets of the form {2i − 1,2j − 1,2r − 1}, where i, j, and r are three different positive integers, and cut sets of the form {2i,2j}, where i and j are two different positive integers. The matrix Λ appearing in the expression hn(p) = π′(M1M2)n1 = π′Λn1 equals

and its derivative with respect to p reads

By Proposition 3.2, the condition required in Proposition 3.1 holds true (for c = 1) for matrices Λ and Λ′ and, therefore, we arrive at the expression

By using the notations Λ′1 = (0,2 − 2p,2 − 2p,1,2p,2p)′ = α and γ = (1,p2,p2,0,−p2,−p2)′ we can write Λ1 = pα + γ, and substituting the quantities hn(p) = π′Λn1 = π′Λn−1Λ1 and hn′(p) = nπ′Λn−1Λ′1 in (3.2), we deduce

where

Should the quantity f (p) be an increasing function of p, the nth member of the family would preserve the IFR property. In the special case considered here, f (p) can be immediately computed as

which is easily checked to be an increasing function of p.
Let us next consider a weighted k-out-of-3:F system with k = 6 and component weights w1 = 2, w2 = 3, and w3 = 4. Then the reliability of the system can be expressed as hn(p) = π′Λ1, where Λ = M1M2M3 and M1 and M2 are as in the previous example and M3 is the following k × k matrix:

The matrix Λ = M1M2M3 equals

and the reliability of the system takes on the form

If we assume that the structure consists of i.i.d. components with (common) survival probabilities p = p(t), then the reliability of the system can be expressed as

and its failure rate equals

On substituting Rn(t) = hn(p(t)) = p(t)(−(p(t))2 + p(t) + 1) we can easily verify that system's failure rate takes on the form

and the monotonicity of the last expression cannot be guaranteed by the monotonicity of (d/dt)[ln p(t)]. For example, if the lifetime distribution p(t) of each component is exponential with p(t) = e−λt,t > 0,λ > 0, the system's failure rate equals

and it can be proved that this quantity is not monotone with respect to t. The last example answers (to the negative) the question of whether the class of weighted-k-out-of-n:F systems preserves the IFR property. However, specific subclasses, such us the one examined in the first example might preserve it.
Acknowledgments
This research is supported by the program Pythagoras, EPEAEK II, Ministry of National Education and Religious Affairs, co-financed by the European Social Fund. The authors wish to thank an anonymous referee for several comments that improved the presentation of the manuscript.


