


1 Introduction
Reduced plasma models play an important role in the analytical and numerical investigations of the complex nonlinear dynamics of magnetized plasmas. The process of dynamical reduction is generally based on the elimination of fast time scales from either kinetic plasma equations or fluid plasma equations. In the kinetic case, the dynamical reduction is usually carried out by considering a sequence of phase-space transformations designed to eliminate a fast orbital time scale (e.g. the time scale associated with the fast gyromotion of a charged particle about a magnetic-field line) from the plasma kinetic equations (e.g. guiding-centre theory). In the fluid case, on the other hand, the fast time scale is often of dynamical origin (e.g. the fast compressional Alfvén wave time scale in a strongly magnetized plasma), and the dynamical reduction involves the identification of a small number of fluid moments and electromagnetic-field components that capture the desired reduced fluid dynamics (e.g. reduced magnetohydrodynamics (MHD)).
Reduced plasma models can be either dissipationless or dissipative, depending on the dynamical time scales of interest. When considering the complex nonlinear dynamics of high-temperature magnetized plasmas (e.g. magnetized fusion plasmas), dissipationless reduced plasma models can offer great mathematical simplicity since the time scales of interest may be much shorter than collisional (dissipative) time scales. Furthermore, when a dissipationless reduced plasma model is shown to possess a Hamiltonian structure, the powerful methods of Hamiltonian field theory can be brought to bear in understanding its analytical and numerical solutions.
A fundamental question thus arises when reducing a system of Hamiltonian field equations: will the dissipationless form of the reduced system possess a Hamiltonian structure? In the case of several reduced dissipationless fluid plasma models derived from Hamiltonian plasma models, the underlying reduced Hamiltonian structure can be constructed from the reduced equations themselves, as was done for MHD (Morrison & Greene Reference Morrison and Greene1980) and many other plasma models (Morrison Reference Morrison1982). Previous works on the Lagrangian (variational) structure of the reduced Vlasov–Maxwell equations (Pfirsch Reference Pfirsch1984; Pfirsch & Morrison Reference Pfirsch and Morrison1985; Brizard Reference Brizard2000a ,Reference Brizard b ) have shown that such a construction is possible and that the reduced Lagrangian formulation (derived by Lie-transform methods) yields crucial information about reduced energy–momentum conservation laws.
The purpose of the present work is to investigate whether the Hamiltonian structure of the reduced Vlasov–Maxwell equations can be constructed directly from the original Hamiltonian structure of these equations. This will be accomplished by the process of lifting introduced in Morrison (Reference Morrison2013) and further developed in Morrison, Vittot & de Guillebon (Reference Morrison, Vittot and de Guillebon2013). The present work is a continuation of these earlier works that allows for greater generality, while casting the formalism in the language of Lie transforms that is commonplace in gyrokinetic theory (Brizard & Hahm Reference Brizard and Hahm2007). An extended version of this paper can be found in the e-print arXiv:1606.06652, where several proofs and additional details are presented. The work presented here introduces the mathematical foundations of the Hamiltonian structure of the reduced Vlasov–Maxwell equations and explicit applications of this reduced Hamiltonian formalism will be considered in future work.
The remainder of this paper is organized as follows. First we consider some preliminary basics in § 2; viz., the definition of what constitutes a Hamiltonian field theory is given and followed by some general comments on coordinate changes. Then, in § 3, we review the Hamiltonian structure of the Vlasov–Maxwell equations, where the Hamiltonian functional and the Vlasov–Maxwell bracket are presented. In § 4, we derive the general transformation (lift) procedure of the Hamiltonian structure of the Vlasov–Maxwell equations based on a general class of phase-space transformations that depends on the electromagnetic fields
 $(\boldsymbol{E},\boldsymbol{B})$
. These transformations are complicated because they depend on both independent and dependent variables; therefore, we introduce operators on functions and meta-operators on functionals to facilitate the transformation of the Vlasov–Maxwell equations as well as the Vlasov–Maxwell Poisson bracket. Following this general phase-space transformation, we therefore show how functional derivatives appearing in the Vlasov–Maxwell bracket are lifted to a new function space.
In § 5, we demonstrate this general lifting procedure by considering a preliminary transformation from particle phase space to local phase-space coordinates that depends on the local magnetic field
 $\boldsymbol{B}(\boldsymbol{x})$
only. As a result of the preliminary local phase-space transformation, however, the evolution of the local Vlasov function now depends explicitly on the fast gyromotion time scale, which must be removed by the near-identity guiding-centre phase-space transformation (see Cary & Brizard (Reference Cary and Brizard2009) for a recent review).
In § 6, we review the process of dynamical reduction of the phase-space particle dynamics by Lie-transform perturbation methods (Brizard Reference Brizard2009). Here, the dynamical reduction requires that a near-identity transformation be applied to the local phase-space coordinates. In § 7, we construct the reduced Vlasov–Maxwell equations by Lie-transform and meta-operator methods and, in § 8, we derive the reduced Vlasov–Maxwell bracket by the application of meta-operators on the Vlasov–Maxwell bracket. We also verify that the reduced Vlasov–Maxwell equations can be expressed as Hamiltonian field equations in terms of the reduced Hamiltonian functional and the reduced Vlasov–Maxwell bracket.
2 Preliminaries
Although Hamiltonian descriptions of plasma dynamical systems are discussed in several sources (Morrison Reference Morrison1982, Reference Morrison1998, Reference Morrison2005), we briefly review here some basics of Hamiltonian field theory, before continuing on to the Vlasov–Maxwell theory.
2.1 General Hamiltonian field theory
The Hamiltonian formulation of a general field theory involving an
 $N$
-component field
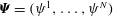 $\unicode[STIX]{x1D733}=(\unicode[STIX]{x1D713}^{1},\ldots ,\unicode[STIX]{x1D713}^{N})$
is expressed in terms of a Hamiltonian functional
 ${\mathcal{H}}[\unicode[STIX]{x1D733}]$
, identified from the energy conservation law of the field equations, and a bracket structure
 $$\begin{eqnarray}[{\mathcal{F}},{\mathcal{G}}]_{\unicode[STIX]{x1D6F9}}\equiv \int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}^{a}(\boldsymbol{r})}\mathbb{J}^{ab}(\unicode[STIX]{x1D733};\boldsymbol{r})\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}^{b}(\boldsymbol{r})},\end{eqnarray}$$
where
 $\int _{\boldsymbol{r}}$
denotes an integration over the base space for the fields
 $\unicode[STIX]{x1D733}$
. Here, the
 $N\times N$
matrix operator
 $\mathbb{J}^{ab}=-\mathbb{J}^{ba}$
is antisymmetric, while
 ${\mathcal{F}}[\unicode[STIX]{x1D733}]$
and
 ${\mathcal{G}}[\unicode[STIX]{x1D733}]$
are arbitrary functionals; summation over repeated indices is implied throughout the manuscript and explicit time dependence is not displayed unless necessary. In addition, functional derivatives
 $\unicode[STIX]{x1D6FF}{\mathcal{F}}/\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}^{a}$
are defined in terms of the Fréchet derivative:
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}{\mathcal{F}}\equiv \left.\frac{\text{d}}{\text{d}\unicode[STIX]{x1D700}}\right|_{\unicode[STIX]{x1D700}=0}{\mathcal{F}}[\unicode[STIX]{x1D733}+\unicode[STIX]{x1D700}\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D733}]=\int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}^{a}(\boldsymbol{r})}\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}^{a}(\boldsymbol{r}),\end{eqnarray}$$
which may involve integration by parts if the functional
 ${\mathcal{F}}$
depends on
 $\unicode[STIX]{x1D735}\unicode[STIX]{x1D713}^{a}$
.
Since the operator
 $\mathbb{J}^{ab}=-\mathbb{J}^{ba}$
is antisymmetric, the bracket (2.1) is also antisymmetric:
 $[{\mathcal{F}},{\mathcal{G}}]_{\unicode[STIX]{x1D6F9}}=-[{\mathcal{G}},{\mathcal{F}}]_{\unicode[STIX]{x1D6F9}}$
and it also possesses the Leibniz property
 $[{\mathcal{F}},{\mathcal{G}}{\mathcal{K}}]_{\unicode[STIX]{x1D6F9}}=[{\mathcal{F}},{\mathcal{G}}]_{\unicode[STIX]{x1D6F9}}{\mathcal{K}}+{\mathcal{G}}[{\mathcal{F}},{\mathcal{K}}]_{\unicode[STIX]{x1D6F9}}$
, where
 ${\mathcal{F}}$
,
 ${\mathcal{G}}$
, and
 ${\mathcal{K}}$
are arbitrary functionals. In addition, it satisfies the Jacobi identity
 $$\begin{eqnarray}[{\mathcal{F}},[{\mathcal{G}},{\mathcal{K}}]_{\unicode[STIX]{x1D6F9}}]_{\unicode[STIX]{x1D6F9}}+[{\mathcal{G}},[{\mathcal{K}},{\mathcal{F}}]_{\unicode[STIX]{x1D6F9}}]_{\unicode[STIX]{x1D6F9}}+[{\mathcal{K}},[{\mathcal{F}},{\mathcal{G}}]_{\unicode[STIX]{x1D6F9}}]_{\unicode[STIX]{x1D6F9}}\equiv 0.\end{eqnarray}$$
Using the Hamiltonian functional
 ${\mathcal{H}}[\unicode[STIX]{x1D733}]$
and the bracket (2.1), the field equations for
 $\unicode[STIX]{x1D733}$
are expressed in Hamiltonian form as
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}{\mathcal{F}}}{\unicode[STIX]{x2202}t}\equiv [{\mathcal{F}},{\mathcal{H}}]_{\unicode[STIX]{x1D6F9}}=\int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}^{a}(\boldsymbol{r})}\left(\mathbb{J}^{ab}(\unicode[STIX]{x1D733};\boldsymbol{r})\frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}^{b}(\boldsymbol{r})}\right)\equiv \int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}^{a}(\boldsymbol{r})}\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D713}^{a}(\boldsymbol{r})}{\unicode[STIX]{x2202}t}.\end{eqnarray}$$
While an antisymmetric matrix operator
 $\mathbb{J}^{ab}$
that satisfies the Leibniz property is relatively easy to construct, the Jacobi identity (2.3) is generally difficult to satisfy. (See Morrison (Reference Morrison1982) where the Jacobi identity is discussed in generality.)
The purpose of the present paper is to investigate how the bracket structure (2.1) is affected by a field transformation
 $\unicode[STIX]{x1D733}\rightarrow \overline{\unicode[STIX]{x1D733}}$
, where the transformation depends on both independent and dependent variables, as noted above, with the new fields
 $\overline{\unicode[STIX]{x1D733}}$
having desirable properties making them amenable to theoretical and/or numerical reduction.
2.2 Functional transformation of a Hamiltonian bracket
As noted above, the question of how Hamiltonian functional brackets transform has recently been studied in the ‘lift’ context by Morrison (Reference Morrison2013) and Morrison et al. (Reference Morrison, Vittot and de Guillebon2013) for the Vlasov–Maxwell equations. In particular, Morrison et al. (Reference Morrison, Vittot and de Guillebon2013) studied the process of lifting associated with a change of momentum-space coordinates
 $\boldsymbol{p}\rightarrow \overline{\boldsymbol{p}}$
(at a fixed particle position
 $\boldsymbol{x}$
) that is dependent on the local magnetic field; this case is revisited here in § 5 using the notation introduced in § 4. Alternatively, one may consider transformations in the context of Dirac constraint theory (Morrison, Lebovitz & Biello Reference Morrison, Lebovitz and Biello2009; Chandre, Morrison & Tassi Reference Chandre, Morrison and Tassi2012; Chandre et al.
Reference Chandre, de Guillebon, Back, Tassi and Morrison2013). In particular, Squire et al. (Reference Squire, Qin, Tang and Chandre2013) considered the construction of a reduced bracket for the gyrokinetic Vlasov–Poisson equations by using this method. Another context is that of ‘beatification’ (Morrison & Vanneste Reference Morrison and Vanneste2016; Viscondi, Caldas & Morrison Reference Viscondi, Caldas and Morrison2016) where one uses transformations to perturbatively remove nonlinearity from the Poisson bracket and place it in the Hamiltonian functional.
In the present paper, we study the lifting of the Vlasov–Maxwell bracket associated with a phase-space coordinate transformation
 $$\begin{eqnarray}{\mathcal{T}}_{\unicode[STIX]{x1D716}}\equiv {\mathcal{T}}^{\unicode[STIX]{x1D716}}\circ {\mathcal{T}}_{0}:\boldsymbol{z}\rightarrow \boldsymbol{z}_{0}\equiv {\mathcal{T}}_{0}\boldsymbol{z}\rightarrow \overline{\boldsymbol{Z}}\equiv {\mathcal{T}}^{\unicode[STIX]{x1D716}}\boldsymbol{z}_{0}\equiv {\mathcal{T}}_{\unicode[STIX]{x1D716}}\boldsymbol{z},\end{eqnarray}$$
which represents the composition of a preliminary phase-space transformation
 ${\mathcal{T}}_{0}$
to local phase-space coordinates
 $\boldsymbol{z}_{0}$
followed by a near-identity phase-space transformation
 ${\mathcal{T}}^{\unicode[STIX]{x1D716}}\equiv \cdots {\mathcal{T}}_{3}{\mathcal{T}}_{2}{\mathcal{T}}_{1}$
to reduced phase-space coordinates
 $\overline{\boldsymbol{Z}}$
that is generated by Lie-transform perturbation methods. The phase-space coordinate transformation (2.5) will be assumed to be invertible, with
 ${\mathcal{T}}_{\unicode[STIX]{x1D716}}^{-1}\equiv {\mathcal{T}}_{0}^{-1}{\mathcal{T}}^{-\unicode[STIX]{x1D716}}$
. (See, e.g. Brizard & Hahm (Reference Brizard and Hahm2007) and Brizard (Reference Brizard2008) for further discussion.)
As in Morrison (Reference Morrison2013), our construction will explicitly guarantee that the reduced Vlasov–Maxwell bracket satisfies the Jacobi identity (2.3), while the reduced functionals will depend on the reduced Vlasov distribution function
 $\overline{F}\equiv \unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}f$
, defined as the push forward
 $\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\unicode[STIX]{x1D61B}_{0}^{-1}$
of the particle Vlasov distribution function
 $f$
and the electromagnetic fields
 $(\boldsymbol{E},\boldsymbol{B})$
. The present reduced Vlasov–Maxwell Hamiltonian formulation uses exclusively the variable
 $\boldsymbol{E}$
, while the earlier work of Morrison (Reference Morrison2013) used both
 $\boldsymbol{E}$
and the electric displacement field
 $\boldsymbol{D}_{\unicode[STIX]{x1D716}}\equiv \boldsymbol{E}+4\unicode[STIX]{x03C0}\boldsymbol{P}_{\unicode[STIX]{x1D716}}$
as a field variable, where
 $\boldsymbol{P}_{\unicode[STIX]{x1D716}}$
denotes the reduced polarization (Brizard Reference Brizard2008, Reference Brizard2013; Tronko & Brizard Reference Tronko and Brizard2015).
3 Hamiltonian structure of the Vlasov–Maxwell equations
We now briefly review of the Hamiltonian structure of the Vlasov–Maxwell equations introduced in Morrison (Reference Morrison1980), with corrections given in Marsden & Weinstein (Reference Marsden and Weinstein1982) and Morrison (Reference Morrison1982). The Hamiltonian functional is simply represented as the energy invariant of the Vlasov–Maxwell equations:
 $$\begin{eqnarray}{\mathcal{H}}[f,\boldsymbol{E},\boldsymbol{B}]=\frac{1}{8\unicode[STIX]{x03C0}}\int _{\boldsymbol{r}}(|\boldsymbol{E}(\boldsymbol{r})|^{2}+|\boldsymbol{B}(\boldsymbol{r})|^{2})+\int _{\boldsymbol{ z}}{\mathcal{J}}(\boldsymbol{z})\,f(\boldsymbol{z})K(\boldsymbol{z}),\end{eqnarray}$$
where the Jacobian
 ${\mathcal{J}}$
is shown explicitly and
 $K=|\boldsymbol{p}|^{2}/(2m)$
denotes the kinetic energy of a particle of mass
 $m$
and charge
 $e$
(summation over particle species is implied whenever applicable).
The Vlasov–Maxwell bracket is a bilinear operator on arbitrary functionals
 ${\mathcal{F}}[f,\boldsymbol{E},\boldsymbol{B}]$
and
 ${\mathcal{G}}[f,\boldsymbol{E},\boldsymbol{B}]$
:
 $$\begin{eqnarray}\displaystyle [{\mathcal{F}},{\mathcal{G}}] & = & \displaystyle \int _{\boldsymbol{z}}{\mathcal{J}}\,f\left\{\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f},\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}f}\right\}+4\unicode[STIX]{x03C0}c\int _{\boldsymbol{r}}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}-\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\right)\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}e\int _{\boldsymbol{z}}{\mathcal{J}}\,f\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\left\{\boldsymbol{x},\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}f}\right\}-\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\left\{\boldsymbol{x},\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f}\right\}\right),\end{eqnarray}$$
where the variation
 $\unicode[STIX]{x1D6FF}{\mathcal{F}}$
of an arbitrary functional
 ${\mathcal{F}}[f,\boldsymbol{E},\boldsymbol{B}]$
is defined in terms of the Fréchet derivative
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}{\mathcal{F}}\equiv \left.\frac{\text{d}}{\text{d}\unicode[STIX]{x1D700}}\right|_{\unicode[STIX]{x1D700}=0}{\mathcal{F}}[f+\unicode[STIX]{x1D700}\unicode[STIX]{x1D6FF}f,\boldsymbol{E}+\unicode[STIX]{x1D700}\unicode[STIX]{x1D6FF}\boldsymbol{E},\boldsymbol{B}+\unicode[STIX]{x1D700}\unicode[STIX]{x1D6FF}\boldsymbol{B}]=\int _{\boldsymbol{z}}\unicode[STIX]{x1D6FF}f\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f}+\int _{\boldsymbol{r}}\left(\unicode[STIX]{x1D6FF}\boldsymbol{E}\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}+\unicode[STIX]{x1D6FF}\boldsymbol{B}\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\right).\end{eqnarray}$$
For the sake of our presentation, the three terms appearing in the bracket (3.2) are called, respectively, the Vlasov, Maxwell and interaction sub-brackets.
The single-particle (non-canonical) Poisson bracket
 $\{\,,\,\}$
appearing (3.2) is defined in terms of functions
 $f$
and
 $g$
on particle phase space as
 $$\begin{eqnarray}\{\,f,g\}=\left(\unicode[STIX]{x1D735}f\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}g}{\unicode[STIX]{x2202}\boldsymbol{p}}-\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}\boldsymbol{p}}\boldsymbol{\cdot }\unicode[STIX]{x1D735}g\right)+\frac{e}{c}\boldsymbol{B}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}\boldsymbol{p}}\times \frac{\unicode[STIX]{x2202}g}{\unicode[STIX]{x2202}\boldsymbol{p}}.\end{eqnarray}$$
The Poisson bracket (3.4) can also be written in divergence form as
 $$\begin{eqnarray}\{\,f,g\}\equiv \frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}J^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}\frac{\unicode[STIX]{x2202}g}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FD}}}=\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}({\mathcal{J}}\,f\{z^{\unicode[STIX]{x1D6FC}},g\}),\end{eqnarray}$$
where the antisymmetric Poisson matrix components
 $J^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}(\boldsymbol{z})\equiv \{z^{\unicode[STIX]{x1D6FC}},z^{\unicode[STIX]{x1D6FD}}\}$
satisfy the Liouville identities
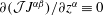 $\unicode[STIX]{x2202}({\mathcal{J}}J^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}})/\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}\equiv 0$
. In what follows, explicit and implicit time dependences are assumed for the Vlasov distribution
 $f$
and the electromagnetic fields
 $(\boldsymbol{E},\boldsymbol{B})$
and time is unaffected by the phase-space transformations considered here. The proof of the Jacobi identity (see appendix A of the e-print arXiv:1606.06652 for details) for the Poisson bracket (3.4):
 $$\begin{eqnarray}\{\,f,\{g,h\}\}+\{g,\{h,f\}\}+\{h,\{\,f,g\}\}=0\end{eqnarray}$$
requires that the magnetic field
 $\boldsymbol{B}$
be divergenceless:
 $\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{B}\equiv 0$
.
The Vlasov–Maxwell bracket (3.2) is antisymmetric
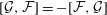 $[{\mathcal{G}},{\mathcal{F}}]=-[{\mathcal{F}},{\mathcal{G}}]$
and satisfies the Leibniz property
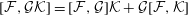 $[{\mathcal{F}},{\mathcal{G}}{\mathcal{K}}]=[{\mathcal{F}},{\mathcal{G}}]{\mathcal{K}}+{\mathcal{G}}[{\mathcal{F}},{\mathcal{K}}]$
. In addition, it was shown in Morrison (Reference Morrison1982) that direct calculation yields the Jacobi identity
 $$\begin{eqnarray}[{\mathcal{F}},[{\mathcal{G}},{\mathcal{K}}]]+[{\mathcal{G}},[{\mathcal{K}},{\mathcal{F}}]]+[{\mathcal{K}},[{\mathcal{F}},{\mathcal{G}}]]\equiv \int _{\boldsymbol{z}}f\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{B}\left(\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\boldsymbol{p}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\boldsymbol{p}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}f}\times \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\boldsymbol{p}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}}{\unicode[STIX]{x1D6FF}f}\right)=0,\end{eqnarray}$$
which requires the condition
 $\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{B}=0$
. Details of the original (onerous and lengthy) calculation were recorded in an appendix of Morrison (Reference Morrison2013), while a simplified version of this calculation is presented in appendix B of the e-print arXiv:1606.06652. Note that the Jacobi condition
 $\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{B}=0$
for the bracket (3.2) is inherited from the Jacobi condition for the Poisson bracket (3.4).
3.1 Vlasov–Maxwell equations
The Hamiltonian evolution of a generic functional
 ${\mathcal{F}}[f,\boldsymbol{E},\boldsymbol{B}]$
is expressed in terms of the Hamiltonian functional (3.1) and the Vlasov–Maxwell bracket (3.2) as
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}{\mathcal{F}}}{\unicode[STIX]{x2202}t}\equiv [{\mathcal{F}},{\mathcal{H}}] & = & \displaystyle -\int _{\boldsymbol{z}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f}(\{\,f,K\}+e\boldsymbol{E}\boldsymbol{\cdot }\{\boldsymbol{x},f\})-\int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\boldsymbol{\cdot }(c\unicode[STIX]{x1D735}\times \boldsymbol{E})\nonumber\\ \displaystyle & & \displaystyle +\,\int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\left(c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}e\int _{\boldsymbol{z}}{\mathcal{J}}f\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r})\{\boldsymbol{x},K\}\right),\end{eqnarray}$$
which becomes
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}{\mathcal{F}}}{\unicode[STIX]{x2202}t}\equiv \int _{\boldsymbol{z}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f(\boldsymbol{z})}\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}t}+\int _{\boldsymbol{r}}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\right),\end{eqnarray}$$
where the Vlasov equation in particle phase space
 $(\boldsymbol{x},\boldsymbol{p}=m\boldsymbol{v})$
is
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}t}=-\boldsymbol{v}\boldsymbol{\cdot }\unicode[STIX]{x1D735}f(\boldsymbol{z})-e\left(\boldsymbol{E}(\boldsymbol{x})+\frac{\boldsymbol{v}}{c}\times \boldsymbol{B}(\boldsymbol{x})\right)\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}f(\boldsymbol{z})}{\unicode[STIX]{x2202}\boldsymbol{p}},\end{eqnarray}$$
and the Maxwell equations are
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}=c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}e\int _{\boldsymbol{z}}{\mathcal{J}}f\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r})\boldsymbol{v}\equiv c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}\boldsymbol{J}(\boldsymbol{r}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}=-c\unicode[STIX]{x1D735}\times \boldsymbol{E}. & \displaystyle\end{eqnarray}$$
The remaining Maxwell equations
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{E}=4\unicode[STIX]{x03C0}e\int _{\boldsymbol{z}}{\mathcal{J}}f\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r})\equiv 4\unicode[STIX]{x03C0}\unicode[STIX]{x1D71A}(\boldsymbol{r}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{B}=0 & \displaystyle\end{eqnarray}$$
can be seen as initial conditions for the electromagnetic fields
 $(\boldsymbol{E},\boldsymbol{B})$
for
 $\unicode[STIX]{x1D735}\boldsymbol{\cdot }(\unicode[STIX]{x2202}\boldsymbol{B}/\unicode[STIX]{x2202}t)=0$
and
 $\unicode[STIX]{x1D735}\boldsymbol{\cdot }(\unicode[STIX]{x2202}\boldsymbol{E}/\unicode[STIX]{x2202}t)=-4\unicode[STIX]{x03C0}\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{J}=4\unicode[STIX]{x03C0}\unicode[STIX]{x2202}\unicode[STIX]{x1D71A}/\unicode[STIX]{x2202}t$
, which represents the charge conservation law and follows from (3.11). We note that the charge density
 $\unicode[STIX]{x1D71A}(\boldsymbol{r})$
and the current density
 $\boldsymbol{J}(\boldsymbol{r})$
are functionals of the Vlasov distribution
 $f(\boldsymbol{z})$
, both labelled by the field position
 $\boldsymbol{r}$
and the presence of the delta function
 $\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r})$
in (3.11) and (3.13) implies that only particles located at
 $\boldsymbol{x}=\boldsymbol{r}$
contribute to the electromagnetic fields
 $(\boldsymbol{E},\boldsymbol{B})$
.
3.2 Hamiltonian properties
The characteristics of the Vlasov equation (3.10) are the equations of motion
 $$\begin{eqnarray}\frac{\text{d}\boldsymbol{x}}{\text{d}t}=\frac{\boldsymbol{p}}{m}\quad \text{and}\quad \frac{\text{d}\boldsymbol{p}}{\text{d}t}=e\boldsymbol{E}(\boldsymbol{x})+\frac{e\boldsymbol{v}}{c}\times \boldsymbol{B}(\boldsymbol{x}),\end{eqnarray}$$
which can be expressed in (non-canonical) Hamiltonian form as (Morrison Reference Morrison2013)
 $$\begin{eqnarray}\frac{\text{d}z^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\equiv \{z^{\unicode[STIX]{x1D6FC}},K\}+e\boldsymbol{E}(\boldsymbol{x})\boldsymbol{\cdot }\{\boldsymbol{x},z^{\unicode[STIX]{x1D6FC}}\}.\end{eqnarray}$$
Hence, the Vlasov equation (3.10) may be expressed as
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}t}+\frac{\text{d}z^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\;\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}=0,\end{eqnarray}$$
which may also be expressed in divergence form as
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}({\mathcal{J}}\,f)}{\unicode[STIX]{x2202}t}=-\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}\left({\mathcal{J}}\,f\frac{\text{d}z^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\right),\end{eqnarray}$$
since the Jacobian
 ${\mathcal{J}}$
satisfies the Liouville theorem
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}{\mathcal{J}}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}\left({\mathcal{J}}\frac{\text{d}z^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\right)=0.\end{eqnarray}$$
Lastly, using (3.9) with (3.11)–(3.12) and (3.18), we easily show that the Hamiltonian functional (3.1) is itself an invariant of the Vlasov–Maxwell dynamics:
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}{\mathcal{H}}}{\unicode[STIX]{x2202}t} & = & \displaystyle \int _{\boldsymbol{r}}\left[\frac{\boldsymbol{E}}{4\unicode[STIX]{x03C0}}\boldsymbol{\cdot }(c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}\boldsymbol{J})-\frac{\boldsymbol{B}}{4\unicode[STIX]{x03C0}}\boldsymbol{\cdot }(c\unicode[STIX]{x1D735}\times \boldsymbol{E})\right]-\int _{\boldsymbol{z}}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}\left({\mathcal{J}}\,f\frac{\text{d}z^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\right)K\nonumber\\ \displaystyle & = & \displaystyle \int _{\boldsymbol{z}}{\mathcal{J}}\,f\left(\frac{\text{d}K}{\text{d}t}-e\boldsymbol{E}\boldsymbol{\cdot }\boldsymbol{v}\right)=0,\end{eqnarray}$$
which vanishes since
 $\text{d}K/\text{d}t=e\boldsymbol{v}\boldsymbol{\cdot }\boldsymbol{E}$
. Equation (3.20), expressed as
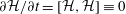 $\unicode[STIX]{x2202}{\mathcal{H}}/\unicode[STIX]{x2202}t=[{\mathcal{H}},{\mathcal{H}}]\equiv 0$
, immediately follows from the antisymmetry of the Vlasov–Maxwell bracket (3.2).
4 General transformation lift of the Vlasov–Maxwell equations
We consider the transformation of the Hamiltonian structure (3.1)–(3.2) of the Vlasov–Maxwell equations associated with a general time-dependent phase-space transformation that depends on the electromagnetic field
 $(\boldsymbol{E},\boldsymbol{B})$
as well as their spatial gradients. Hence, we consider a phase-space transformation
 ${\mathcal{T}}:\boldsymbol{z}\rightarrow \overline{\boldsymbol{Z}}$
that is also invertible
 ${\mathcal{T}}^{-1}:\overline{\boldsymbol{Z}}\rightarrow \boldsymbol{z}$
.
In the next sections, we will consider the two-step transformation process (2.5) encountered in the dynamical reduction of charged-particle motion in a strong magnetic field (e.g. guiding-centre transformation (Cary & Brizard Reference Cary and Brizard2009)). In the first step (§ 5), we present the preliminary transformation
 ${\mathcal{T}}_{0}$
from particle phase-space coordinates
 $(\boldsymbol{x},\boldsymbol{p})$
to local phase-space coordinates
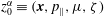 $z_{0}^{\unicode[STIX]{x1D6FC}}\equiv (\boldsymbol{x},p_{\Vert },\unicode[STIX]{x1D707},\unicode[STIX]{x1D701})$
, where
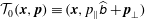 ${\mathcal{T}}_{0}(\boldsymbol{x},\boldsymbol{p})\equiv (\boldsymbol{x},p_{\Vert }\widehat{\unicode[STIX]{x1D623}}+\boldsymbol{p}_{\bot })$
.
The preliminary phase-space transformation introduces explicit dependence on the fast gyromotion time scale (through the local gyroangle
 $\unicode[STIX]{x1D701}$
). In the second step (§ 6), we present the near-identity phase-space transformation
 ${\mathcal{T}}^{\unicode[STIX]{x1D716}}\equiv \cdots {\mathcal{T}}_{2}{\mathcal{T}}_{1}$
to the reduced phase-space coordinates
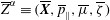 $\overline{Z}^{\unicode[STIX]{x1D6FC}}\equiv (\overline{\boldsymbol{X}},\overline{p}_{\Vert },\overline{\unicode[STIX]{x1D707}},\overline{\unicode[STIX]{x1D701}})$
generated by Lie-transform perturbation methods.
4.1 General operators on functions and functionals
A general phase-space transformation
 ${\mathcal{T}}$
induces operators on phase-space functions and meta-operators on functionals. First, the push-forward operator
 $\unicode[STIX]{x1D61B}^{-1}:f\rightarrow \overline{f}\equiv \unicode[STIX]{x1D61B}^{-1}f$
transforms a function
 $f$
on particle phase space into a function
 $\overline{f}$
on the new phase space. In addition, the pull-back operator
 $\unicode[STIX]{x1D61B}:\overline{f}\rightarrow f\equiv \unicode[STIX]{x1D61B}\overline{f}$
transforms a function
 $\overline{f}$
on the new phase space into a function
 $f$
on particle phase space. These operator definitions ensure that the scalar-covariance properties are satisfied:
 $f(\boldsymbol{z})=f({\mathcal{T}}^{-1}\overline{\boldsymbol{Z}})=\unicode[STIX]{x1D61B}^{-1}f(\overline{\boldsymbol{Z}})=\overline{f}(\overline{\boldsymbol{Z}})$
and
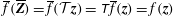 $\overline{f}(\overline{\boldsymbol{Z}})=\overline{f}({\mathcal{T}}\boldsymbol{z})=\unicode[STIX]{x1D61B}\overline{f}(\boldsymbol{z})=f(\boldsymbol{z})$
. The transformed Jacobian
 $\overline{{\mathcal{J}}}$
is defined from the push-forward relation
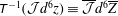 $\unicode[STIX]{x1D61B}^{-1}({\mathcal{J}}d^{6}z)\equiv \overline{{\mathcal{J}}}d^{6}\overline{Z}$
, where
 $d^{6}z$
and
 $d^{6}\overline{Z}$
denote differential six-forms in their respective phase spaces.
Secondly, we introduce the meta-push-forward functional operator
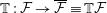 $\mathbb{T}:{\mathcal{F}}\rightarrow \overline{{\mathcal{F}}}\equiv \mathbb{T}{\mathcal{F}}$
and the meta-pull-back functional operator
 $\mathbb{T}^{-1}:\overline{{\mathcal{F}}}\rightarrow {\mathcal{F}}\equiv \mathbb{T}^{-1}\overline{{\mathcal{F}}}$
, which satisfy the functional-covariance properties, e.g.
 $\overline{{\mathcal{F}}}[\overline{f}]=\mathbb{T}{\mathcal{F}}[\overline{f}]={\mathcal{F}}[\unicode[STIX]{x1D61B}\overline{f}]={\mathcal{F}}[f]$
.
4.2 Transformed Vlasov–Maxwell equations
The transformation of the Vlasov equation (3.17) proceeds through the push-forward transformation of each of its parts:
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}t}\right)=-\unicode[STIX]{x1D61B}^{-1}(\{\,f,K\}+e\boldsymbol{E}\boldsymbol{\cdot }\{\boldsymbol{x},f\}).\end{eqnarray}$$
While time is unaffected by the phase-space transformations considered here, we note that the partial-time derivative
 $\unicode[STIX]{x2202}/\unicode[STIX]{x2202}t$
does not commute with the push-forward operator
 $\unicode[STIX]{x1D61B}^{-1}$
and, thus, the commutation relation
 $[\unicode[STIX]{x1D61B}^{-1},\unicode[STIX]{x2202}/\unicode[STIX]{x2202}t]$
must be calculated carefully.
4.2.1 Transformed partial-time derivative
On the left-hand side of (4.1), we introduce the transformed partial-time derivative
 $\overline{\unicode[STIX]{x2202}}/\unicode[STIX]{x2202}t$
:
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}t}\right)=\left[\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}t}\unicode[STIX]{x1D61B}\right)\right]\unicode[STIX]{x1D61B}^{-1}f\equiv \frac{\overline{\unicode[STIX]{x2202}}\,\overline{f}}{\unicode[STIX]{x2202}t},\end{eqnarray}$$
which is defined by the operator-commutation identity
 $$\begin{eqnarray}\frac{\overline{\unicode[STIX]{x2202}}\,\overline{f}}{\unicode[STIX]{x2202}t}\equiv \frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}t}+\left[\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}t}\unicode[STIX]{x1D61B}\right)-\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}t}\right]\overline{f}\equiv \frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}t}+\frac{\overline{\unicode[STIX]{x2202}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}},\end{eqnarray}$$
where the second term is a partial-differential operator in the new phase space:
 $$\begin{eqnarray}\frac{\overline{\unicode[STIX]{x2202}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\equiv \unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x2202}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x2202}t}\right).\end{eqnarray}$$
Note that, for a time-independent phase-space transformation, the operators
 $\unicode[STIX]{x2202}/\unicode[STIX]{x2202}t$
and
 $\unicode[STIX]{x1D61B}^{-1}$
commute and
 $\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x2202}f/\unicode[STIX]{x2202}t)=\unicode[STIX]{x2202}(\unicode[STIX]{x1D61B}^{-1}f)/\unicode[STIX]{x2202}t=\unicode[STIX]{x2202}\overline{f}/\unicode[STIX]{x2202}t$
.
4.2.2 Transformed Poisson bracket
On the right-hand side of (4.1), we define the transformed Poisson bracket
 $\overline{\{\,,\,\}}$
on the new phase space from the identity (Brizard Reference Brizard2008)
 $$\begin{eqnarray}\overline{\{\overline{f},\overline{g}\}}\equiv \unicode[STIX]{x1D61B}^{-1}(\{\,f,g\})\equiv \unicode[STIX]{x1D61B}^{-1}(\{\unicode[STIX]{x1D61B}\overline{f},\unicode[STIX]{x1D61B}\overline{g}\})\equiv \frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D707}}}\overline{J}^{\unicode[STIX]{x1D707}\unicode[STIX]{x1D708}}\frac{\unicode[STIX]{x2202}\overline{g}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D708}}},\end{eqnarray}$$
where the transformed Poisson matrix
 $\overline{J}^{\unicode[STIX]{x1D707}\unicode[STIX]{x1D708}}$
is defined in terms of the particle Poisson matrix
 $J^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}\equiv \{z^{\unicode[STIX]{x1D6FC}},z^{\unicode[STIX]{x1D6FD}}\}$
as
 $$\begin{eqnarray}\overline{J}^{\unicode[STIX]{x1D707}\unicode[STIX]{x1D708}}\equiv \unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x2202}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D707}})}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}J^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}\frac{\unicode[STIX]{x2202}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D708}})}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FD}}}\right)=\unicode[STIX]{x1D61B}^{-1}(\{\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D707}},\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D708}}\})\equiv \overline{\{\overline{Z}^{\unicode[STIX]{x1D707}},\overline{Z}^{\unicode[STIX]{x1D708}}\}}.\end{eqnarray}$$
The transformed Poisson bracket (4.5) is guaranteed to satisfy the Jacobi identity because it is derived from a transformed Lagrange two-form
 $\overline{\unicode[STIX]{x1D714}}\equiv \unicode[STIX]{x1D61B}^{-1}\unicode[STIX]{x1D714}=\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D625}\unicode[STIX]{x1D6FE})=\unicode[STIX]{x1D625}(\unicode[STIX]{x1D61B}^{-1}\unicode[STIX]{x1D6FE})\equiv \unicode[STIX]{x1D625}\overline{\unicode[STIX]{x1D6FE}}$
that is closed
 $\unicode[STIX]{x1D625}\overline{\unicode[STIX]{x1D714}}\equiv 0$
.
The transformed Poisson bracket (4.5) is expressed in phase-space divergence form as
 $$\begin{eqnarray}\overline{\{\overline{f},\overline{g}\}}\equiv \frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}(\overline{{\mathcal{J}}}\,\overline{f}\,\overline{\{\overline{Z}^{\unicode[STIX]{x1D6FC}},\overline{g}\}}),\end{eqnarray}$$
which follows from the Liouville identities
 $\unicode[STIX]{x2202}(\overline{{\mathcal{J}}}\,\overline{J}^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}})/\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}\equiv 0$
. Using the definition (4.5), the right-hand side of (4.1) now becomes
 $$\begin{eqnarray}-\unicode[STIX]{x1D61B}^{-1}(\{\,f,K\}+e\boldsymbol{E}\boldsymbol{\cdot }\{\boldsymbol{x},f\})=-\overline{\{\overline{f},\overline{K}\}}-e\unicode[STIX]{x1D61B}^{-1}\boldsymbol{E}\boldsymbol{\cdot }\overline{\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\overline{f}\}},\end{eqnarray}$$
where
 $\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x}$
denotes the push forward of the particle position
 $\boldsymbol{x}$
and
 $\unicode[STIX]{x1D61B}^{-1}\boldsymbol{E}$
denotes the push forward of the electric field as it appears in the reduced particle dynamics.
4.2.3 Transformed Vlasov equation
By combining (4.2) and (4.8), we obtain the transformed Vlasov equation
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}t}=-\left[\overline{\{\overline{Z}^{\unicode[STIX]{x1D6FC}},\overline{K}\}}+e\unicode[STIX]{x1D61B}^{-1}\boldsymbol{E}\boldsymbol{\cdot }\overline{\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\overline{Z}^{\unicode[STIX]{x1D6FC}}\}}+\frac{\overline{\unicode[STIX]{x2202}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\right]\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\equiv -\frac{\overline{\text{d}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}},\end{eqnarray}$$
where the transformed phase-space dynamics
 $\overline{\text{d}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}/\text{d}t$
includes the transformed partial-time derivative (4.4) as well as the transformed Hamilton equations
 $$\begin{eqnarray}\dot{\overline{Z}}^{\unicode[STIX]{x1D6FC}}\equiv \overline{\{\overline{Z}^{\unicode[STIX]{x1D6FC}},\overline{K}\}}+e\unicode[STIX]{x1D61B}^{-1}\boldsymbol{E}\boldsymbol{\cdot }\overline{\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\overline{Z}^{\unicode[STIX]{x1D6FC}}\}}.\end{eqnarray}$$
Next, the transformed Liouville theorem requires that the transformed Jacobian
 $\overline{{\mathcal{J}}}$
satisfies the evolution equation
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}\overline{{\mathcal{J}}}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\left(\overline{{\mathcal{J}}}\frac{\overline{\text{d}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\right)=0.\end{eqnarray}$$
Since the transformed Hamilton equations (4.10) satisfy the identity
 $\unicode[STIX]{x2202}(\overline{{\mathcal{J}}}\,\dot{\overline{Z}}^{\unicode[STIX]{x1D6FC}})/\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}\equiv 0$
, the transformed Jacobian, therefore, satisfies the equation
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}\overline{{\mathcal{J}}}}{\unicode[STIX]{x2202}t}=-\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\left(\overline{{\mathcal{J}}}\frac{\overline{\unicode[STIX]{x2202}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\right)=-\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\left[\overline{{\mathcal{J}}}\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x2202}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x2202}t}\right)\right].\end{eqnarray}$$
Moreover, the transformed Vlasov equation (4.9) can be written in divergence form as
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}(\overline{{\mathcal{J}}}\,\overline{f})}{\unicode[STIX]{x2202}t}=-\overline{{\mathcal{J}}}\left(\dot{\overline{Z}}^{\unicode[STIX]{x1D6FC}}+\frac{\overline{\unicode[STIX]{x2202}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\right)\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}-\overline{f}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\left(\overline{{\mathcal{J}}}\frac{\overline{\unicode[STIX]{x2202}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\right)=-\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\left(\overline{{\mathcal{J}}}\,\overline{f}\frac{\overline{\text{d}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\right).\end{eqnarray}$$
4.2.4 Transformed Maxwell equations
Lastly, we turn our attention to the transformation of the Maxwell equations (3.11)–(3.14). Of course, (3.12) and (3.14) are unchanged by the phase-space transformation since they are source free. The Maxwell equations (3.11) and (3.13), however, become
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t} & = & \displaystyle c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}e\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\unicode[STIX]{x1D6FF}^{3}(\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x}-\boldsymbol{r})\frac{\overline{\text{d}}(\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x})}{\text{d}t}\nonumber\\ \displaystyle & \equiv & \displaystyle c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}\mathbb{T}\boldsymbol{J}(\boldsymbol{r}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{E}=4\unicode[STIX]{x03C0}e\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\unicode[STIX]{x1D6FF}^{3}(\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x}-\boldsymbol{r})\equiv 4\unicode[STIX]{x03C0}\mathbb{T}\unicode[STIX]{x1D71A}(\boldsymbol{r}), & \displaystyle\end{eqnarray}$$
where the meta-push-forward
 $\mathbb{T}$
is applied on the particle current density in (3.11) and the particle charge density in (3.13), which are both functionals labelled by the field position
 $\boldsymbol{r}$
. In (4.14), the push forward of the particle velocity is defined as
 $$\begin{eqnarray}\frac{\overline{\text{d}}(\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x})}{\text{d}t}=\unicode[STIX]{x1D61B}^{-1}\left(\frac{\text{d}\boldsymbol{x}}{\text{d}t}\right)=\overline{\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\overline{K}\}},\end{eqnarray}$$
where we used the identities
 $\overline{\unicode[STIX]{x2202}}(\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x})/\unicode[STIX]{x2202}t\equiv \unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x2202}\boldsymbol{x}/\unicode[STIX]{x2202}t)\equiv 0$
(i.e. the particle position
 $\boldsymbol{x}$
does not explicitly depend on time) and
 $\overline{\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x}\}}\equiv \unicode[STIX]{x1D61B}^{-1}(\{\boldsymbol{x},\boldsymbol{x}\})=0$
.
4.3 Transformed functional variations
The variation of an arbitrary functional
 $\overline{{\mathcal{F}}}[\overline{f},\boldsymbol{E},\boldsymbol{B}]$
is defined in terms of the Fréchet derivative (3.3), which can be transformed to yield
 $$\begin{eqnarray}\displaystyle \mathbb{T}[\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{F}}})] & = & \displaystyle \int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}f)\unicode[STIX]{x1D61B}^{-1}\left[\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}f}\right]\nonumber\\ \displaystyle & & \displaystyle +\,\int _{\boldsymbol{r}}\left(\unicode[STIX]{x1D6FF}\boldsymbol{E}\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}+\unicode[STIX]{x1D6FF}\boldsymbol{B}\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\right).\end{eqnarray}$$
Here, the push forward of the variation
 $\unicode[STIX]{x1D6FF}f$
on particle phase space:
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}f)=\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}^{-1}f)+([\unicode[STIX]{x1D61B}^{-1},\unicode[STIX]{x1D6FF}]\unicode[STIX]{x1D61B})\unicode[STIX]{x1D61B}^{-1}f\equiv \unicode[STIX]{x1D6FF}\overline{f}+([\unicode[STIX]{x1D61B}^{-1},\unicode[STIX]{x1D6FF}]\unicode[STIX]{x1D61B})\overline{f}\end{eqnarray}$$
is expressed in terms of the transformed variation
 $\unicode[STIX]{x1D6FF}\overline{f}$
on the new phase space and the commutation operator
 $$\begin{eqnarray}([\unicode[STIX]{x1D61B}^{-1},\unicode[STIX]{x1D6FF}]\unicode[STIX]{x1D61B})=\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D61B})-\unicode[STIX]{x1D6FF}\equiv \unicode[STIX]{x1D61B}^{-1}[\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})]\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}},\end{eqnarray}$$
which is similar to the commutator (4.3), with
 $\unicode[STIX]{x2202}/\unicode[STIX]{x2202}t$
replaced by
 $\unicode[STIX]{x1D6FF}$
. Hence, (4.18) can be expressed as
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}f)=\unicode[STIX]{x1D6FF}\overline{f}+\unicode[STIX]{x1D61B}^{-1}[\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})]\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\equiv \unicode[STIX]{x1D6FF}\overline{f}+\int _{\boldsymbol{r}}[\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{E}}\overline{f}+\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}\overline{f}],\end{eqnarray}$$
where the differential operators
 $\unicode[STIX]{x2202}_{\boldsymbol{E}}$
and
 $\unicode[STIX]{x2202}_{\boldsymbol{B}}$
are defined as
 $$\begin{eqnarray}\unicode[STIX]{x2202}_{\boldsymbol{E}}\equiv \unicode[STIX]{x1D61B}^{-1}\left[\frac{\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\right]\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\quad \text{and}\quad \unicode[STIX]{x2202}_{\boldsymbol{B}}\equiv \unicode[STIX]{x1D61B}^{-1}\left[\frac{\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\right]\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}.\end{eqnarray}$$
If we now use the identity
 $\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}\equiv \mathbb{T}[\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{F}}})]$
in (4.17), we obtain the functional-variation relations
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D61B}^{-1}\left[\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}f}\right]\equiv \frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\equiv \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}-\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x2202}_{\boldsymbol{E}}\overline{f}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\equiv \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{F}}}(\boldsymbol{r}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\equiv \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x2202}_{\boldsymbol{B}}\overline{f}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\equiv \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{F}}}(\boldsymbol{r}). & \displaystyle\end{eqnarray}$$
Hence, the meta-pull-back operator
 $\mathbb{T}^{-1}$
introduces electromagnetic shifts
 $(\unicode[STIX]{x1D6E5}_{\boldsymbol{E}},\unicode[STIX]{x1D6E5}_{\boldsymbol{B}})$
in the functional derivatives (4.23)–(4.24) that are due to the dependence of the phase-space transformation on the electromagnetic fields
 $(\boldsymbol{E},\boldsymbol{B})$
, as shown in (4.21).
4.4 Transformed Hamiltonian functional
As an application of the transformed functional variations (4.22)–(4.24), we consider the transformed Hamiltonian functional
 $\overline{{\mathcal{H}}}$
obtained from the meta-push-forward of the Hamiltonian functional (3.1):
 $$\begin{eqnarray}\overline{{\mathcal{H}}}\equiv \mathbb{T}{\mathcal{H}}=\frac{1}{8\unicode[STIX]{x03C0}}\int _{\boldsymbol{r}}(|\boldsymbol{E}|^{2}+|\boldsymbol{B}|^{2})+\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\,\overline{K},\end{eqnarray}$$
where
 $\overline{K}\equiv \unicode[STIX]{x1D61B}^{-1}K$
is the transformed kinetic energy. First, the functional variation of
 $\overline{{\mathcal{H}}}$
yields
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}=\int _{\boldsymbol{r}}\left(\unicode[STIX]{x1D6FF}\boldsymbol{E}\boldsymbol{\cdot }\frac{\boldsymbol{E}}{4\unicode[STIX]{x03C0}}+\unicode[STIX]{x1D6FF}\boldsymbol{B}\boldsymbol{\cdot }\frac{\boldsymbol{B}}{4\unicode[STIX]{x03C0}}\right)+\int _{\overline{\boldsymbol{Z}}}[\unicode[STIX]{x1D6FF}\overline{f}\,\overline{{\mathcal{J}}}\,\overline{K}+\overline{f}\unicode[STIX]{x1D6FF}(\overline{{\mathcal{J}}}\,\overline{K})],\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6FF}(\overline{{\mathcal{J}}}\,\overline{K})=\unicode[STIX]{x1D6FF}\overline{{\mathcal{J}}}\,\overline{K}+\overline{{\mathcal{J}}}\;\unicode[STIX]{x1D6FF}\overline{K}$
. Here, we have
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}\overline{{\mathcal{J}}}=-\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}[\overline{{\mathcal{J}}}\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})],\end{eqnarray}$$
which follows from (4.12), while
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}\overline{K}=\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}^{-1}K)=\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}K)-([\unicode[STIX]{x1D61B}^{-1},\unicode[STIX]{x1D6FF}]\unicode[STIX]{x1D61B})\unicode[STIX]{x1D61B}^{-1}K\equiv -\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})\frac{\unicode[STIX]{x2202}\overline{K}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}},\end{eqnarray}$$
where we used
 $\unicode[STIX]{x1D6FF}K\equiv 0$
(i.e. the particle kinetic energy
 $K$
does not depend on
 $\boldsymbol{E}$
and
 $\boldsymbol{B}$
).
Next, by combining (4.27)–(4.28), we find
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}(\overline{{\mathcal{J}}}\,\overline{K})=-\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}[\overline{{\mathcal{J}}}\,\overline{K}\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})],\end{eqnarray}$$
so that integration by parts of this term in (4.26) yields
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}} & = & \displaystyle \int _{\boldsymbol{r}}\left(\unicode[STIX]{x1D6FF}\boldsymbol{E}\boldsymbol{\cdot }\frac{\boldsymbol{E}}{4\unicode[STIX]{x03C0}}+\unicode[STIX]{x1D6FF}\boldsymbol{B}\boldsymbol{\cdot }\frac{\boldsymbol{B}}{4\unicode[STIX]{x03C0}}\right)+\int _{\overline{\boldsymbol{Z}}}\left[\unicode[STIX]{x1D6FF}\overline{f}\,\overline{{\mathcal{J}}}\,\overline{K}+\overline{{\mathcal{J}}}\,\overline{K}[\unicode[STIX]{x1D61B}^{-1}(\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})]\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\right]\nonumber\\ \displaystyle & \equiv & \displaystyle \int _{\boldsymbol{r}}\left(\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}+\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\right)+\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D6FF}\overline{f}(\overline{\boldsymbol{Z}})\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\overline{f}(\overline{\boldsymbol{Z}})},\end{eqnarray}$$
where we find the functional variations
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\overline{f}}=\overline{{\mathcal{J}}}\,\overline{K}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}=\frac{\boldsymbol{E}}{4\unicode[STIX]{x03C0}}+\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x2202}_{\boldsymbol{E}}\overline{f}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\equiv \frac{\boldsymbol{E}}{4\unicode[STIX]{x03C0}}+\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{H}}}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}=\frac{\boldsymbol{B}}{4\unicode[STIX]{x03C0}}+\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x2202}_{\boldsymbol{B}}\overline{f}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\equiv \frac{\boldsymbol{B}}{4\unicode[STIX]{x03C0}}+\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{H}}}. & \displaystyle\end{eqnarray}$$
Hence, substituting (4.31)–(4.33) into (4.22)–(4.24) yields
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D61B}^{-1}\left[\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{H}}})}{\unicode[STIX]{x1D6FF}f}\right]\equiv \frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\overline{f}}=\overline{K}\equiv \unicode[STIX]{x1D61B}^{-1}\left(\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}}{\unicode[STIX]{x1D6FF}f}\right), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{H}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\equiv \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{H}}}(\boldsymbol{r})=\frac{\boldsymbol{E}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}\equiv \frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}^{-1}\overline{{\mathcal{H}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\equiv \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{H}}}(\boldsymbol{r})=\frac{\boldsymbol{B}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}\equiv \frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}, & \displaystyle\end{eqnarray}$$
where we see that the terms
 $(\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{H}}},\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{H}}})$
are exactly cancelled in the functional derivatives (4.32)–(4.33), which is not the case for a general transformed functional
 $\overline{{\mathcal{F}}}$
.
4.5 Transformed Vlasov–Maxwell bracket
The transformed Vlasov–Maxwell bracket is now constructed in a three-step process with the help of the meta-operators
 $\mathbb{T}^{-1}$
and
 $\mathbb{T}$
. First, we note that the Vlasov–Maxwell functional bracket (3.2) is itself a functional and thus transforms as a functional under the action of the meta-push-forward
 $\mathbb{T}$
. Hence, we express the meta-push-forward of the Vlasov–Maxwell functional bracket (3.2) as
 $$\begin{eqnarray}\displaystyle \mathbb{T}([{\mathcal{F}},{\mathcal{G}}]) & = & \displaystyle \int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\left[\unicode[STIX]{x1D61B}^{-1}\left(\left\{{\mathcal{J}}^{-1}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f},{\mathcal{J}}^{-1}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}f}\right\}\right)\right]+[\text{Maxwell sub}\text{-}\text{bracket}]\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}e\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\left[\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}\right)\boldsymbol{\cdot }\unicode[STIX]{x1D61B}^{-1}\left(\left\{\boldsymbol{x},{\mathcal{J}}^{-1}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}f}\right\}\right)\right.\nonumber\\ \displaystyle & & \displaystyle -\left.\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}\right)\boldsymbol{\cdot }\unicode[STIX]{x1D61B}^{-1}\left(\left\{\boldsymbol{x},{\mathcal{J}}^{-1}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f}\right\}\right)\right],\end{eqnarray}$$
where the Maxwell sub-bracket is unaffected by the meta-push-forward (since it is independent of the Vlasov distribution function) and we used the distributivity property of the push-forward operation
 $\unicode[STIX]{x1D61B}^{-1}$
in the interaction sub-bracket.
Next, we insert the definition of the transformed Poisson bracket (4.5) to obtain
 $$\begin{eqnarray}\displaystyle \mathbb{T}([{\mathcal{F}},{\mathcal{G}}]) & = & \displaystyle \int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\overline{\left\{\unicode[STIX]{x1D61B}^{-1}\left({\mathcal{J}}^{-1}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f}\right),\unicode[STIX]{x1D61B}^{-1}\left({\mathcal{J}}^{-1}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}f}\right)\right\}}+[\text{Maxwell sub}\text{-}\text{bracket}]\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}e\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\left[\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}\right)\boldsymbol{\cdot }\overline{\left\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\unicode[STIX]{x1D61B}^{-1}\left({\mathcal{J}}^{-1}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}f}\right)\right\}}\right.\nonumber\\ \displaystyle & & \displaystyle -\left.\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}\right)\boldsymbol{\cdot }\overline{\left\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\unicode[STIX]{x1D61B}^{-1}\left({\mathcal{J}}^{-1}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}}{\unicode[STIX]{x1D6FF}f}\right)\right\}}\right].\end{eqnarray}$$
Lastly, we use the meta-pull-back operation
 $\mathbb{T}^{-1}$
to replace the particle functionals
 ${\mathcal{F}}$
and
 ${\mathcal{G}}$
with the transformed functionals
 ${\mathcal{F}}=\mathbb{T}^{-1}\overline{{\mathcal{F}}}$
and
 ${\mathcal{G}}=\mathbb{T}^{-1}\overline{{\mathcal{G}}}$
, which yields the transformed Vlasov–Maxwell bracket
 $\overline{[\overline{{\mathcal{F}}},\overline{{\mathcal{G}}}]}\equiv \mathbb{T}([\mathbb{T}^{-1}\overline{{\mathcal{F}}},\mathbb{T}^{-1}\overline{{\mathcal{G}}}])$
:
 $$\begin{eqnarray}\displaystyle \overline{[\overline{{\mathcal{F}}},\overline{{\mathcal{G}}}]} & = & \displaystyle \int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\overline{\left\{\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}},\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{G}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\right\}}\nonumber\\ \displaystyle & & \displaystyle +\,4\unicode[STIX]{x03C0}c\int _{\boldsymbol{r}}\left[\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{F}}}(\boldsymbol{r})\right)\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{G}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{G}}}(\boldsymbol{r})\right)\right.\nonumber\\ \displaystyle & & \displaystyle -\left.\!\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{G}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{G}}}(\boldsymbol{r})\right)\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{F}}}(\boldsymbol{r})\right)\right]\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}e\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\left[\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{F}}}(\boldsymbol{x})\right)\boldsymbol{\cdot }\overline{\left\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{G}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\right\}}\right.\nonumber\\ \displaystyle & & \displaystyle -\left.\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{G}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{G}}}(\boldsymbol{x})\right)\boldsymbol{\cdot }\overline{\left\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\right\}}\right],\end{eqnarray}$$
where we substituted the transformed functional variations (4.22)–(4.24). The bracket (4.39) is similar in form to the bracket (47) of Morrison (Reference Morrison2013), but is restricted since it is essentially a restatement of Vlasov–Maxwell theory, while the bracket of Morrison (Reference Morrison2013) applies to a larger class of theories. We immediately note that the transformed Vlasov–Maxwell bracket (4.39) automatically satisfies the Jacobi identity
 $$\begin{eqnarray}\displaystyle 0 & = & \displaystyle \overline{[\overline{[\overline{{\mathcal{F}}},\overline{{\mathcal{G}}}]},\overline{{\mathcal{H}}}]}+\overline{[\overline{[\overline{{\mathcal{G}}},\overline{{\mathcal{H}}}]},\overline{{\mathcal{F}}}]}+\overline{[\overline{[\overline{{\mathcal{H}}},\overline{{\mathcal{F}}}]},\overline{{\mathcal{G}}}]}\nonumber\\ \displaystyle & \equiv & \displaystyle \mathbb{T}([[{\mathcal{F}},{\mathcal{G}}],{\mathcal{H}}]+[[{\mathcal{G}},{\mathcal{H}}],{\mathcal{F}}]+[[{\mathcal{H}},{\mathcal{F}}],{\mathcal{G}}]),\end{eqnarray}$$
since the original Vlasov–Maxwell bracket (3.2) satisfies the Jacobi identity.
We now show that the transformed Vlasov–Maxwell equations (4.9), (4.14) and (3.12) can be expressed in Hamiltonian form as
 $\overline{[\overline{{\mathcal{F}}},\overline{{\mathcal{H}}}]}$
, where
 $$\begin{eqnarray}\displaystyle \overline{[\overline{{\mathcal{F}}},\overline{{\mathcal{H}}}]} & = & \displaystyle \int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\overline{\left\{\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}},\overline{K}\right\}}\nonumber\\ \displaystyle & & \displaystyle +\,c\int _{\boldsymbol{r}}\left[\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{F}}}\right)\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \boldsymbol{B}-\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{F}}}\right)\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \boldsymbol{E}\right]\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}e\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\left[\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{F}}}(\boldsymbol{x})\right)\boldsymbol{\cdot }\overline{\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\overline{K}\}}\right.\nonumber\\ \displaystyle & & \displaystyle -\left.\unicode[STIX]{x1D61B}^{-1}\left(\frac{\boldsymbol{E}(\boldsymbol{x})}{4\unicode[STIX]{x03C0}}\right)\boldsymbol{\cdot }\overline{\left\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\right\}}\right],\end{eqnarray}$$
where we used (4.34)–(4.36). Upon integration by parts, we obtain
 $$\begin{eqnarray}\displaystyle \overline{[\overline{{\mathcal{F}}},\overline{{\mathcal{H}}}]} & = & \displaystyle -\int _{\overline{\boldsymbol{Z}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}(\overline{\{\overline{f},\overline{K}\}}+e\unicode[STIX]{x1D61B}^{-1}\boldsymbol{E}\boldsymbol{\cdot }\overline{\{\unicode[STIX]{x1D61B}^{-1}\boldsymbol{x},\overline{f}\}})-\int _{\boldsymbol{r}}\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{F}}}\right)\boldsymbol{\cdot }(c\unicode[STIX]{x1D735}\times \boldsymbol{E})\nonumber\\ \displaystyle & & \displaystyle +\,\int _{\boldsymbol{r}}\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{F}}}\right)\boldsymbol{\cdot }[c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}\mathbb{T}\boldsymbol{J}(\boldsymbol{r})]\nonumber\\ \displaystyle & \equiv & \displaystyle \int _{\overline{\boldsymbol{Z}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}t}+\int _{\boldsymbol{r}}\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\right),\end{eqnarray}$$
where we used
 $$\begin{eqnarray}\displaystyle & & \displaystyle \int _{\boldsymbol{r}}[\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}\overline{{\mathcal{F}}}\boldsymbol{\cdot }(c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}\mathbb{T}\boldsymbol{J})+\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}\overline{{\mathcal{F}}}\boldsymbol{\cdot }(-c\unicode[STIX]{x1D735}\times \boldsymbol{E})]\nonumber\\ \displaystyle & & \displaystyle \quad =\int _{\boldsymbol{r}}\int _{\overline{\boldsymbol{Z}}}\left(\frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{E}}\overline{f}+\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}\overline{f}\right)\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\nonumber\\ \displaystyle & & \displaystyle \quad =\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D61B}^{-1}\left(\frac{\unicode[STIX]{x2202}(\unicode[STIX]{x1D61B}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x2202}t}\right)\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\equiv \int _{\overline{\boldsymbol{Z}}}\frac{\overline{\unicode[STIX]{x2202}}\,\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}.\end{eqnarray}$$
We have thus shown that, as a result of a general phase-space transformation
 ${\mathcal{T}}$
, the transformed Vlasov–Maxwell equations possess a Hamiltonian structure that is constructed by operators
 $(\unicode[STIX]{x1D61B},\unicode[STIX]{x1D61B}^{-1})$
and meta-operators
 $(\mathbb{T},\mathbb{T}^{-1})$
derived from the phase-space transformation. Here, the transformed Hamiltonian functional (4.25) is defined as the meta-push-forward of the Hamiltonian functional
 $\overline{{\mathcal{H}}}\equiv \mathbb{T}{\mathcal{H}}$
, while the transformed Vlasov–Maxwell bracket (4.39) is defined as
 $\overline{[\overline{{\mathcal{F}}},\overline{{\mathcal{G}}}]}\equiv \mathbb{T}([\mathbb{T}^{-1}\overline{{\mathcal{F}}},\mathbb{T}^{-1}\overline{{\mathcal{G}}}])$
.
5 Local Vlasov–Maxwell equations
Reduced Vlasov–Maxwell equations are often derived through a preliminary phase-space transformation
 ${\mathcal{T}}_{0}$
from the particle phase-space coordinates
 $(\boldsymbol{x},\boldsymbol{p})$
to the local phase-space coordinates
 $(\boldsymbol{x},p_{\Vert },p_{\bot },\unicode[STIX]{x1D701})$
derived from the local magnetic field
 $\boldsymbol{B}(\boldsymbol{x})\equiv B\widehat{\unicode[STIX]{x1D623}}$
, where
 $p_{\Vert }\equiv \boldsymbol{p}\boldsymbol{\cdot }\widehat{\unicode[STIX]{x1D623}}$
denotes the parallel component of the particle’s momentum along the (local) magnetic-field unit vector at the particle’s position
 $\boldsymbol{x}$
, and
 $p_{\bot }\equiv |\boldsymbol{p}\times \widehat{\unicode[STIX]{x1D623}}|$
denotes the magnitude of the perpendicular component of the particle’s momentum. It is also convenient to express
 $p_{\bot }\equiv (2m\unicode[STIX]{x1D707}B)^{1/2}$
in terms of the lowest-order magnetic moment
 $\unicode[STIX]{x1D707}(\boldsymbol{x},\boldsymbol{p})\equiv |\boldsymbol{p}\times \widehat{\unicode[STIX]{x1D623}}|^{2}/(2mB)$
for guiding-centre (Littlejohn Reference Littlejohn1983) and gyrocentre applications (Brizard & Hahm Reference Brizard and Hahm2007). The local gyroangle
 $\unicode[STIX]{x1D701}$
denotes the orientation of the particle’s perpendicular momentum in the (local) plane perpendicular to
 $\widehat{\unicode[STIX]{x1D623}}$
, which is defined in terms of the differential equation
 $\widehat{\bot }\equiv \unicode[STIX]{x2202}\widehat{\unicode[STIX]{x1D70C}}/\unicode[STIX]{x2202}\unicode[STIX]{x1D701}$
, where the plane locally perpendicular to
 $\widehat{\unicode[STIX]{x1D623}}\equiv \widehat{\bot }\times \widehat{\unicode[STIX]{x1D70C}}$
is defined in terms of two arbitrary rotating unit vectors
 $(\widehat{\bot },\widehat{\unicode[STIX]{x1D70C}})$
. The local momentum is, thus, decomposed under the action of
 ${\mathcal{T}}_{0}$
as
 $$\begin{eqnarray}{\mathcal{T}}_{0}(\boldsymbol{x},\boldsymbol{p})\equiv (\boldsymbol{x},p_{\Vert }(\boldsymbol{x},\boldsymbol{p})\widehat{\unicode[STIX]{x1D623}}(\boldsymbol{x})+p_{\bot }(\boldsymbol{x},\boldsymbol{p})\widehat{\bot }(\boldsymbol{x},\unicode[STIX]{x1D701})).\end{eqnarray}$$
With the local phase-space coordinates
 $(\boldsymbol{x},p_{\Vert },\unicode[STIX]{x1D707},\unicode[STIX]{x1D701})$
, the Jacobian is
 ${\mathcal{J}}_{0}=mB$
. Lastly, we note that, at constant
 $(\boldsymbol{x},\boldsymbol{p})$
, the local momentum coordinates
 $(p_{\Vert },\unicode[STIX]{x1D707},\unicode[STIX]{x1D701})$
are time-dependent functions through their dependence on
 $\boldsymbol{B}$
. The results presented in this section unify the results presented in the recent paper by Morrison et al. (Reference Morrison, Vittot and de Guillebon2013) and highlight the notation introduced in § 4.
5.1 Local Hamiltonian dynamics
Local particle Hamiltonian dynamics is expressed in terms of the local kinetic energy
 $K_{0}=p_{\Vert }^{2}/2m+\unicode[STIX]{x1D707}B$
and a local Poisson bracket constructed as follows. We begin with the local non-canonical one-form
 $\unicode[STIX]{x1D6FE}_{0}=[(e/c)\boldsymbol{A}(\boldsymbol{x})+p_{\Vert }\widehat{\unicode[STIX]{x1D623}}(\boldsymbol{x})+p_{\bot }(\unicode[STIX]{x1D707},\boldsymbol{x})\widehat{\bot }(\unicode[STIX]{x1D701},\boldsymbol{x})]\boldsymbol{\cdot }\unicode[STIX]{x1D625}\boldsymbol{x}$
, from which we obtain the local Lagrange two-form
 $\unicode[STIX]{x1D74E}_{0}=\unicode[STIX]{x1D625}\unicode[STIX]{x1D6FE}_{0}\equiv (1/2)\unicode[STIX]{x1D714}_{0\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}\,\unicode[STIX]{x1D625}z_{0}^{\unicode[STIX]{x1D6FC}}\wedge \unicode[STIX]{x1D625}z_{0}^{\unicode[STIX]{x1D6FD}}$
:
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D74E}_{0}=\frac{e}{2c}B_{0}^{\ast k}\unicode[STIX]{x1D700}_{ijk}\,\unicode[STIX]{x1D625}x^{i}\wedge \unicode[STIX]{x1D625}x^{j}+\unicode[STIX]{x1D625}p_{\Vert }\wedge \widehat{\unicode[STIX]{x1D623}}\boldsymbol{\cdot }\unicode[STIX]{x1D625}\boldsymbol{x}+\frac{\unicode[STIX]{x2202}p_{\bot }}{\unicode[STIX]{x2202}\unicode[STIX]{x1D707}}\,\unicode[STIX]{x1D625}\unicode[STIX]{x1D707}\wedge \widehat{\bot }\boldsymbol{\cdot }\unicode[STIX]{x1D625}\boldsymbol{x}-p_{\bot }\,\unicode[STIX]{x1D625}\unicode[STIX]{x1D701}\wedge \widehat{\unicode[STIX]{x1D70C}}\boldsymbol{\cdot }\unicode[STIX]{x1D625}\boldsymbol{x}, & \displaystyle\end{eqnarray}$$
where the divergenceless local canonical magnetic field
 $$\begin{eqnarray}\displaystyle \boldsymbol{B}_{0}^{\ast } & \equiv & \displaystyle \unicode[STIX]{x1D735}\times \left[\boldsymbol{A}+\frac{c}{e}(p_{\Vert }\widehat{\unicode[STIX]{x1D623}}+p_{\bot }(\unicode[STIX]{x1D707},B)\widehat{\bot })\right]\nonumber\\ \displaystyle & = & \displaystyle \boldsymbol{B}+\frac{cp_{\Vert }}{e}\unicode[STIX]{x1D735}\times \widehat{\unicode[STIX]{x1D623}}+\frac{cp_{\bot }}{e}\left(\unicode[STIX]{x1D735}\times \widehat{\bot }-\frac{1}{2}\widehat{\bot }\times \unicode[STIX]{x1D735}\ln B\right)\end{eqnarray}$$
includes contributions from the local kinetic particle momentum. Next, we derive the local Poisson matrix (with components
 $J_{0}^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}$
) as the inverse of the Lagrange matrix (with components
 $\unicode[STIX]{x1D714}_{0\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}$
), which yields the local Poisson bracket
 $$\begin{eqnarray}\displaystyle \{\,f,g\}_{0} & \equiv & \displaystyle \frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}}J_{0}^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}\frac{\unicode[STIX]{x2202}g}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FD}}}=\unicode[STIX]{x1D735}f\boldsymbol{\cdot }\boldsymbol{\unicode[STIX]{x2202}}g-\boldsymbol{\unicode[STIX]{x2202}}f\boldsymbol{\cdot }\unicode[STIX]{x1D735}g+\frac{e}{c}\boldsymbol{B}_{0}^{\ast }\boldsymbol{\cdot }(\boldsymbol{\unicode[STIX]{x2202}}f\times \boldsymbol{\unicode[STIX]{x2202}}g)\nonumber\\ \displaystyle & = & \displaystyle \frac{1}{{\mathcal{J}}_{0}}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}}({\mathcal{J}}_{0}\,f\{z_{0}^{\unicode[STIX]{x1D6FC}},g\}_{0}),\end{eqnarray}$$
where
 $\boldsymbol{\unicode[STIX]{x2202}}$
denotes the local momentum-space gradient:
 $$\begin{eqnarray}\boldsymbol{\unicode[STIX]{x2202}}f\equiv \widehat{\unicode[STIX]{x1D623}}\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}p_{\Vert }}+\widehat{\bot }\frac{p_{\bot }}{mB}\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}\unicode[STIX]{x1D707}}-\frac{\widehat{\unicode[STIX]{x1D70C}}}{p_{\bot }}\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}\unicode[STIX]{x1D701}}\equiv \widehat{\unicode[STIX]{x1D623}}\unicode[STIX]{x2202}_{\Vert }\,f+\boldsymbol{\unicode[STIX]{x2202}}_{\bot }\,f.\end{eqnarray}$$
We note that the local Poisson bracket (5.4) automatically satisfies the Jacobi property since the local Jacobi condition
 $\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{B}_{0}^{\ast }=0$
is automatically satisfied by (5.3).
The Hamilton equations (3.16) are given in local particle phase space in terms of the local kinetic energy
 $K_{0}$
and the local Poisson bracket (5.4) as
 $$\begin{eqnarray}{\dot{z}}_{0}^{\unicode[STIX]{x1D6FC}}\equiv \{z_{0}^{\unicode[STIX]{x1D6FC}},K_{0}\}_{0}+e\boldsymbol{E}\boldsymbol{\cdot }\{\boldsymbol{x},z_{0}^{\unicode[STIX]{x1D6FC}}\}_{0},\end{eqnarray}$$
where we used
 $\unicode[STIX]{x1D61B}_{0}^{-1}\boldsymbol{x}\equiv \boldsymbol{x}$
and
 $\unicode[STIX]{x1D61B}_{0}^{-1}\boldsymbol{E}\equiv \boldsymbol{E}$
. We note that (5.6) satisfies the local Liouville theorem
 $\unicode[STIX]{x2202}({\mathcal{J}}_{0}{\dot{z}}_{0}^{\unicode[STIX]{x1D6FC}})/\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}=0$
. We also note that when
 $\dot{\unicode[STIX]{x1D707}}_{0}$
is averaged with respect to the local gyroangle
 $\unicode[STIX]{x1D701}$
:
 $\langle \dot{\unicode[STIX]{x1D707}}_{0}\rangle \equiv \oint \dot{\unicode[STIX]{x1D707}}_{0}\,\text{d}\unicode[STIX]{x1D701}/(2\unicode[STIX]{x03C0})$
, we find
 $\langle \dot{\unicode[STIX]{x1D707}}_{0}\rangle =-\unicode[STIX]{x1D707}_{0}[(p_{\Vert }/mB)(\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{B})]=0$
, which is a necessary requirement for the adiabatic invariance of the guiding-centre magnetic moment (Cary & Brizard Reference Cary and Brizard2009).
Using (5.6), the local Vlasov equation is now expressed as
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}_{0}\,f_{0}}{\unicode[STIX]{x2202}t}\equiv \frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}}=-\dot{\boldsymbol{x}}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}f_{0}-{\dot{p}}_{\Vert 0}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}p_{\Vert }}-\dot{\unicode[STIX]{x1D707}}_{0}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D707}}-\dot{\unicode[STIX]{x1D701}}_{0}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D701}},\end{eqnarray}$$
where the local time partial derivative
 $\unicode[STIX]{x2202}_{0}/\unicode[STIX]{x2202}t\equiv \unicode[STIX]{x1D61B}_{0}^{-1}(\unicode[STIX]{x2202}\unicode[STIX]{x1D61B}_{0}/\unicode[STIX]{x2202}t)$
is derived below (see (5.20)), with
 $\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}/\unicode[STIX]{x2202}t$
evaluated at constant
 $(\boldsymbol{x},\boldsymbol{p})$
. We note that, since the local Hamilton equations (5.6) depend explicitly on the local gyroangle
 $\unicode[STIX]{x1D701}$
, the local Vlasov function
 $f_{0}$
evolves rapidly on the gyromotion time scale.
Lastly, the local Maxwell equations are
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}=c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}e\int _{\boldsymbol{z}_{0}}\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r}){\mathcal{J}}_{0}\,f_{0}\dot{\boldsymbol{x}}_{0}\equiv c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}\boldsymbol{J}_{0}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{E}(\boldsymbol{r})=4\unicode[STIX]{x03C0}e\int _{\boldsymbol{z}_{0}}\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r}){\mathcal{J}}_{0}\,f_{0}\equiv 4\unicode[STIX]{x03C0}\unicode[STIX]{x1D71A}_{0}, & \displaystyle\end{eqnarray}$$
while the source-free Maxwell equations (3.12) and (3.14) remain unchanged. We now show that the local Vlasov–Maxwell equations (3.12) and (5.7)–(5.8) possess a Hamiltonian formulation.
5.2 Local coordinate and field variations
The particle velocity is represented in terms of components of the local magnetic field and, thus, the local particle phase-space coordinates acquire an explicit dependence on the magnetic field (Morrison et al. Reference Morrison, Vittot and de Guillebon2013).
5.2.1 Local coordinate variations
Since the definition of the local phase-space coordinates depends on the local magnetic field
 $\boldsymbol{B}\equiv B\widehat{\unicode[STIX]{x1D623}}$
, they are susceptible to variations
 $\unicode[STIX]{x1D6FF}\boldsymbol{B}\equiv \unicode[STIX]{x1D6FF}B\widehat{\unicode[STIX]{x1D623}}+B\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}$
in the magnetic field
 $\boldsymbol{B}=B\widehat{\unicode[STIX]{x1D623}}$
. Hence, at fixed
 $(\boldsymbol{x},\boldsymbol{p})$
, we can calculate
 $\unicode[STIX]{x1D61B}_{0}^{-1}[\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{0}z_{0}^{\unicode[STIX]{x1D6FC}})]\equiv \unicode[STIX]{x1D6FF}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}$
for each local coordinate
 $z_{0}^{\unicode[STIX]{x1D6FC}}$
, with
 $\unicode[STIX]{x1D6FF}_{0}\boldsymbol{x}\equiv 0$
.
We begin with
 $\unicode[STIX]{x1D6FF}_{0}p_{\Vert }$
: first,
 $\unicode[STIX]{x1D61B}_{0}p_{\Vert }\equiv \boldsymbol{p}\boldsymbol{\cdot }\widehat{\unicode[STIX]{x1D623}}$
, so that
 $\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{0}p_{\Vert })\equiv \boldsymbol{p}\boldsymbol{\cdot }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}$
; next,
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}_{0}^{-1}[\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{0}p_{\Vert })]\equiv (\unicode[STIX]{x1D61B}_{0}^{-1}\boldsymbol{p})\boldsymbol{\cdot }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}=(p_{\Vert }\widehat{\unicode[STIX]{x1D623}}+p_{\bot }\widehat{\bot })\boldsymbol{\cdot }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}.\end{eqnarray}$$
By using the identity
 $\widehat{\unicode[STIX]{x1D623}}\boldsymbol{\cdot }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}\equiv 0$
, where
 $\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}\equiv \unicode[STIX]{x1D6FF}(\boldsymbol{B}/B)=(\boldsymbol{I}-\widehat{\unicode[STIX]{x1D623}}\widehat{\unicode[STIX]{x1D623}})\boldsymbol{\cdot }\unicode[STIX]{x1D6FF}\boldsymbol{B}/B$
, we thus find
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}_{0}p_{\Vert }=p_{\bot }\widehat{\bot }\boldsymbol{\cdot }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}.\end{eqnarray}$$
Similarly, we find
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}_{0}p_{\bot }=\unicode[STIX]{x1D61B}_{0}^{-1}[\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{0}p_{\bot })]=\unicode[STIX]{x1D61B}_{0}^{-1}[\boldsymbol{p}\times \unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}\boldsymbol{\cdot }(\boldsymbol{p}\times \widehat{\unicode[STIX]{x1D623}}/|\boldsymbol{p}\times \widehat{\unicode[STIX]{x1D623}}|)]=-p_{\Vert }\widehat{\bot }\boldsymbol{\cdot }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}},\end{eqnarray}$$
and, thus, the local variation of the magnetic moment is
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}_{0}\unicode[STIX]{x1D707}=\unicode[STIX]{x1D6FF}_{0}\left(\frac{p_{\bot }^{2}}{2mB}\right)=\frac{p_{\bot }}{mB}\unicode[STIX]{x1D6FF}_{0}p_{\bot }-\unicode[STIX]{x1D707}\widehat{\unicode[STIX]{x1D623}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}\boldsymbol{B}}{B}\equiv -\left(\frac{p_{\bot }p_{\Vert }}{mB}\widehat{\bot }+\unicode[STIX]{x1D707}\widehat{\unicode[STIX]{x1D623}}\right)\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}\boldsymbol{B}}{B}.\end{eqnarray}$$
We note that the variations (5.11)–(5.13) satisfy the energy conservation law
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}_{0}K_{0}=\frac{p_{\Vert }}{m}\unicode[STIX]{x1D6FF}_{0}p_{\Vert }+\unicode[STIX]{x1D6FF}_{0}\unicode[STIX]{x1D707}B+\unicode[STIX]{x1D707}\unicode[STIX]{x1D6FF}B\equiv 0.\end{eqnarray}$$
The expression for the gyroangle variation
 $\unicode[STIX]{x1D6FF}_{0}\unicode[STIX]{x1D701}$
is derived as follows. From the identity
 $\unicode[STIX]{x1D6FF}_{0}(\unicode[STIX]{x1D61B}_{0}^{-1}\boldsymbol{p})\equiv 0$
, we find the vector identity
 $$\begin{eqnarray}0\equiv \unicode[STIX]{x1D6FF}_{0}p_{\Vert }\widehat{\unicode[STIX]{x1D623}}+p_{\Vert }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}+\unicode[STIX]{x1D6FF}_{0}p_{\bot }\widehat{\bot }+p_{\bot }\unicode[STIX]{x1D6FF}_{0}\widehat{\bot }.\end{eqnarray}$$
Using (5.11), the parallel component of (5.15) yields the identity
 $p_{\bot }\unicode[STIX]{x1D6FF}_{0}(\widehat{\unicode[STIX]{x1D623}}\boldsymbol{\cdot }\widehat{\bot })\equiv 0$
, while its component along
 $\widehat{\bot }$
is identically zero from (5.12). The remaining component is along
 $\widehat{\unicode[STIX]{x1D70C}}$
:
 $p_{\Vert }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}\boldsymbol{\cdot }\widehat{\unicode[STIX]{x1D70C}}+p_{\bot }\unicode[STIX]{x1D6FF}_{0}\widehat{\bot }\boldsymbol{\cdot }\widehat{\unicode[STIX]{x1D70C}}\equiv 0$
. Using the definition
 $\widehat{\unicode[STIX]{x1D70C}}\equiv -\unicode[STIX]{x2202}\widehat{\bot }/\unicode[STIX]{x2202}\unicode[STIX]{x1D701}$
, we thus find
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}_{0}\unicode[STIX]{x1D701}\equiv \frac{p_{\Vert }}{p_{\bot }}\widehat{\unicode[STIX]{x1D70C}}\boldsymbol{\cdot }\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}.\end{eqnarray}$$
Lastly, we note the local coordinate variations (5.11), (5.13) and (5.16) satisfy the divergence property
 $\unicode[STIX]{x2202}(\unicode[STIX]{x1D6FF}_{0}z_{0}^{\unicode[STIX]{x1D6FC}})/\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}=-\unicode[STIX]{x1D6FF}\ln B$
. We also have the local partial-time derivatives
 $\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}/\unicode[STIX]{x2202}t$
, which are obtained from the expressions for
 $\unicode[STIX]{x1D6FF}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}$
by substituting
 $\unicode[STIX]{x1D6FF}\widehat{\unicode[STIX]{x1D623}}$
with
 $\unicode[STIX]{x2202}\widehat{\unicode[STIX]{x1D623}}/\unicode[STIX]{x2202}t$
. These local partial derivatives satisfy the divergence property
 $\unicode[STIX]{x2202}(\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}/\unicode[STIX]{x2202}t)/\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}=-\unicode[STIX]{x2202}\ln B/\unicode[STIX]{x2202}t$
, which yields
 $\unicode[STIX]{x2202}{\mathcal{J}}_{0}/\unicode[STIX]{x2202}t=\unicode[STIX]{x2202}({\mathcal{J}}_{0}\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}/\unicode[STIX]{x2202}t)/\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}$
(with
 ${\mathcal{J}}_{0}=mB$
) as a special case of the general equation (4.12) for the transformed Jacobian
 $\overline{{\mathcal{J}}}$
.
5.2.2 Local field variations
We now introduce the pull-back and push-forward operators associated with the local phase-space transformation:
 $f\equiv \unicode[STIX]{x1D61B}_{0}\,f_{0}$
and
 $f_{0}\equiv \unicode[STIX]{x1D61B}_{0}^{-1}f$
. Using these operators, we construct the relation between the variation
 $\unicode[STIX]{x1D6FF}f$
in particle phase space and the variation
 $\unicode[STIX]{x1D6FF}f_{0}$
in local particle phase space.
For this purpose, we begin with the push-forward expression
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}_{0}^{-1}(\unicode[STIX]{x1D6FF}f)=\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{0}^{-1}f)+([\unicode[STIX]{x1D61B}_{0}^{-1},\unicode[STIX]{x1D6FF}]\unicode[STIX]{x1D61B}_{0})\unicode[STIX]{x1D61B}_{0}^{-1}f\equiv \unicode[STIX]{x1D6FF}f_{0}+([\unicode[STIX]{x1D61B}_{0}^{-1},\unicode[STIX]{x1D6FF}]\unicode[STIX]{x1D61B}_{0})\,f_{0},\end{eqnarray}$$
where, using (5.11)–(5.16), the commutation operator
 $[\unicode[STIX]{x1D61B}_{0}^{-1},\unicode[STIX]{x1D6FF}]\unicode[STIX]{x1D61B}_{0}$
is defined as
 $$\begin{eqnarray}\displaystyle ([\unicode[STIX]{x1D61B}_{0}^{-1},\unicode[STIX]{x1D6FF}]\unicode[STIX]{x1D61B}_{0})\,f_{0} & \equiv & \displaystyle \unicode[STIX]{x1D6FF}_{0}\,f_{0}=\unicode[STIX]{x1D6FF}_{0}p_{\Vert }\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}p_{\Vert }}+\unicode[STIX]{x1D6FF}_{0}\unicode[STIX]{x1D707}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D707}}+\unicode[STIX]{x1D6FF}_{0}\unicode[STIX]{x1D701}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D701}}\nonumber\\ \displaystyle & = & \displaystyle \unicode[STIX]{x1D6FF}\boldsymbol{B}\boldsymbol{\cdot }\left(\frac{\unicode[STIX]{x1D6FF}_{0}p_{\Vert }}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}p_{\Vert }}+\frac{\unicode[STIX]{x1D6FF}_{0}\unicode[STIX]{x1D707}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D707}}+\frac{\unicode[STIX]{x1D6FF}_{0}\unicode[STIX]{x1D701}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D701}}\right)\nonumber\\ \displaystyle & = & \displaystyle \frac{\unicode[STIX]{x1D6FF}\boldsymbol{B}}{B}\boldsymbol{\cdot }\left[(p_{\bot }\widehat{\bot }\unicode[STIX]{x2202}_{\Vert }f_{0}-p_{\Vert }\boldsymbol{\unicode[STIX]{x2202}}_{\bot }\,f_{0})-\widehat{\unicode[STIX]{x1D623}}\unicode[STIX]{x1D707}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D707}}\right]\equiv \unicode[STIX]{x1D6FF}\boldsymbol{B}\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}\,f_{0}.\end{eqnarray}$$
By inserting (5.18) into (5.17), the push forward
 $\unicode[STIX]{x1D61B}_{0}^{-1}(\unicode[STIX]{x1D6FF}f)$
is now expressed in terms of
 $\unicode[STIX]{x1D6FF}f_{0}$
and
 $\unicode[STIX]{x1D6FF}\boldsymbol{B}$
as
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}_{0}^{-1}(\unicode[STIX]{x1D6FF}f)=\unicode[STIX]{x1D6FF}f_{0}+\unicode[STIX]{x1D6FF}\boldsymbol{B}\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}\,f_{0},\end{eqnarray}$$
which agrees with (12) and (32) of Morrison et al. (Reference Morrison, Vittot and de Guillebon2013).
Another application of the push-forward relation (5.17) involves replacing the operator
 $\unicode[STIX]{x1D6FF}$
with
 $\unicode[STIX]{x2202}/\unicode[STIX]{x2202}t$
in order to derive an expression for the local partial-time derivative
 $\unicode[STIX]{x2202}_{0}/\unicode[STIX]{x2202}t$
used in (5.7):
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}_{0}\,f_{0}}{\unicode[STIX]{x2202}t}\equiv \unicode[STIX]{x1D61B}_{0}^{-1}\left(\frac{\unicode[STIX]{x2202}f}{\unicode[STIX]{x2202}t}\right)\equiv \frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}t}+\left(\left[\unicode[STIX]{x1D61B}_{0}^{-1},\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}t}\right]\unicode[STIX]{x1D61B}_{0}\right)f_{0}\equiv \frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}\,f_{0}.\end{eqnarray}$$
Returning to the local Vlasov equation (5.7), we therefore find
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}f_{0}=-\dot{\boldsymbol{x}}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}f_{0}-{\dot{p}}_{\Vert 0}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}p_{\Vert }}-\dot{\unicode[STIX]{x1D707}}_{0}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D707}}-\dot{\unicode[STIX]{x1D701}}_{0}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D701}}.\end{eqnarray}$$
Next, we use the identity
 $(\unicode[STIX]{x2202}\boldsymbol{B}/\unicode[STIX]{x2202}t)\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}\,f_{0}=(\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}/\unicode[STIX]{x2202}t)\unicode[STIX]{x2202}f_{0}/\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}$
and we define the total local time derivative
 $$\begin{eqnarray}\frac{\text{d}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\equiv \frac{\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}+{\dot{z}}_{0}^{\unicode[STIX]{x1D6FC}}\equiv \frac{\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}+\{z_{0}^{\unicode[STIX]{x1D6FC}},K_{0}\}_{0}+e\boldsymbol{E}\boldsymbol{\cdot }\{\boldsymbol{x},z_{0}^{\unicode[STIX]{x1D6FC}}\}_{0},\end{eqnarray}$$
with
 $\unicode[STIX]{x2202}\boldsymbol{x}/\unicode[STIX]{x2202}t\equiv 0$
, so that the local Vlasov equation (5.21) becomes
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}t}=-\frac{\text{d}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}},\end{eqnarray}$$
which can also be expressed in divergence form as
 $\unicode[STIX]{x2202}({\mathcal{J}}_{0}\,f_{0})/\unicode[STIX]{x2202}t=-\unicode[STIX]{x2202}({\mathcal{J}}_{0}f_{0}\,\text{d}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}/\text{d}t)/\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}$
.
5.3 Local functionals
Our next step is now to define a transformation from functionals
 ${\mathcal{F}}[f,\boldsymbol{E},\boldsymbol{B}]$
to functionals
 ${\mathcal{F}}_{0}[f_{0},\boldsymbol{E},\boldsymbol{B}]$
based on the scalar-covariance property:
 ${\mathcal{F}}[f,\boldsymbol{E},\boldsymbol{B}]={\mathcal{F}}_{0}[f_{0},\boldsymbol{E},\boldsymbol{B}]$
. Using (4.22)–(4.24), we find
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D61B}_{0}^{-1}\left[\frac{1}{{\mathcal{J}}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}[\unicode[STIX]{x1D61B}_{0}^{-1}f,\boldsymbol{E},\boldsymbol{B}]}{\unicode[STIX]{x1D6FF}f(\boldsymbol{z})}\right]\equiv \frac{1}{{\mathcal{J}}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}(\boldsymbol{z}_{0})}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}[\unicode[STIX]{x1D61B}_{0}^{-1}f,\boldsymbol{E},\boldsymbol{B}]}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\equiv \frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}[\unicode[STIX]{x1D61B}_{0}^{-1}f,\boldsymbol{E},\boldsymbol{B}]}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})} & \equiv & \displaystyle \frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\int _{\boldsymbol{z}_{0}}\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r})\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}(\boldsymbol{z}_{0})}\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}\,f_{0}\nonumber\\ \displaystyle & \equiv & \displaystyle \frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(0)}{\mathcal{F}}_{0}(\boldsymbol{r}).\end{eqnarray}$$
As an application of (5.24)–(5.26), we consider the local Hamiltonian functional
 $$\begin{eqnarray}{\mathcal{H}}_{0}=\int _{\boldsymbol{r}}\left(\frac{|\boldsymbol{E}|^{2}}{8\unicode[STIX]{x03C0}}+\frac{|\boldsymbol{B}|^{2}}{8\unicode[STIX]{x03C0}}\right)+\int _{\boldsymbol{z}_{0}}{\mathcal{J}}_{0}\,f_{0}K_{0},\end{eqnarray}$$
from which we obtain
 $\unicode[STIX]{x1D6FF}{\mathcal{H}}_{0}/\unicode[STIX]{x1D6FF}f_{0}={\mathcal{J}}_{0}K_{0}$
and
 $\unicode[STIX]{x1D6FF}{\mathcal{H}}_{0}/\unicode[STIX]{x1D6FF}\boldsymbol{E}=\boldsymbol{E}/4\unicode[STIX]{x03C0}$
, while
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})} & = & \displaystyle \frac{\boldsymbol{B}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}+\int _{\boldsymbol{z}_{0}}\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r})\,f_{0}\frac{\unicode[STIX]{x1D6FF}({\mathcal{J}}_{0}K_{0})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\nonumber\\ \displaystyle & = & \displaystyle \frac{\boldsymbol{B}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}+\int _{\boldsymbol{z}_{0}}\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r}){\mathcal{J}}_{0}\,f_{0}\left[\frac{\widehat{\unicode[STIX]{x1D623}}}{B}(K_{0}+\unicode[STIX]{x1D707}B)\right].\end{eqnarray}$$
On the other hand, equation (5.26) yields
 $$\begin{eqnarray}\frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}_{0}[\unicode[STIX]{x1D61B}_{0}^{-1}f,\boldsymbol{E},\boldsymbol{B}]}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}=\frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(0)}{\mathcal{H}}_{0}(\boldsymbol{r}),\end{eqnarray}$$
 $$\begin{eqnarray}\frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}_{0}[\unicode[STIX]{x1D61B}_{0}^{-1}f,\boldsymbol{E},\boldsymbol{B}]}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}=\frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(0)}{\mathcal{H}}_{0}(\boldsymbol{r})\equiv \frac{\boldsymbol{B}}{4\unicode[STIX]{x03C0}},\end{eqnarray}$$
where we used the identity
 $$\begin{eqnarray}\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(0)}{\mathcal{H}}_{0}=\int _{\boldsymbol{z}_{0}}\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r}){\mathcal{J}}_{0}K_{0}\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}f_{0}=\int _{\boldsymbol{z}_{0}}\unicode[STIX]{x1D6FF}^{3}(\boldsymbol{x}-\boldsymbol{r}){\mathcal{J}}_{0}\,f_{0}\left[\frac{\widehat{\unicode[STIX]{x1D623}}}{B}\frac{\unicode[STIX]{x2202}(\unicode[STIX]{x1D707}K_{0})}{\unicode[STIX]{x2202}\unicode[STIX]{x1D707}}\right]\equiv \frac{\unicode[STIX]{x1D6FF}{\mathcal{H}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\frac{\boldsymbol{B}}{4\unicode[STIX]{x03C0}}.\end{eqnarray}$$
5.4 Local Vlasov–Maxwell bracket
Now that we have calculated the local functional variations (5.24)–(5.26), we can transform the Vlasov–Maxwell bracket (3.2) and obtain the local Vlasov–Maxwell bracket
 $$\begin{eqnarray}\displaystyle [{\mathcal{F}}_{0},{\mathcal{G}}_{0}]_{0} & \equiv & \displaystyle \mathbb{T}_{0}([\mathbb{T}_{0}^{-1}{\mathcal{F}}_{0},\mathbb{T}_{0}^{-1}{\mathcal{G}}_{0}])\nonumber\\ \displaystyle & = & \displaystyle \int _{\boldsymbol{z}_{0}}{\mathcal{J}}_{0}\,f_{0}\left\{\frac{1}{{\mathcal{J}}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}},\frac{1}{{\mathcal{J}}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}}\right\}_{0}\nonumber\\ \displaystyle & & \displaystyle +\,4\unicode[STIX]{x03C0}c\int _{\boldsymbol{r}}\left[\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(0)}{\mathcal{G}}_{0}\right)-\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(0)}{\mathcal{F}}_{0}\right)\right]\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}e\int _{\boldsymbol{z}_{0}}{\mathcal{J}}_{0}\,f_{0}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\left\{\boldsymbol{x},\frac{1}{{\mathcal{J}}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}}\right\}_{0}-\frac{\unicode[STIX]{x1D6FF}{\mathcal{G}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\left\{\boldsymbol{x},\frac{1}{{\mathcal{J}}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}}\right\}_{0}\right).\end{eqnarray}$$
We note that this form is generic to all phase-space transformations that depend on the magnetic field only. In addition, because the local Poisson bracket
 $\{\;\}_{0}$
also depends on magnetic-field gradients (e.g.
 $\unicode[STIX]{x1D735}\times \widehat{\unicode[STIX]{x1D623}}$
in
 $\boldsymbol{B}_{0}^{\ast }$
), the Jacobi identity (3.7) for the local bracket
 $[\,,\,]_{0}$
might be difficult to prove explicitly.
We now show that the local Vlasov–Maxwell equations (3.12) and (5.7)–(5.8) can be formulated in Hamiltonian form as
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}{\mathcal{F}}_{0}}{\unicode[STIX]{x2202}t}=[{\mathcal{F}}_{0},{\mathcal{H}}_{0}]_{0}\equiv \int _{\boldsymbol{z}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}t}+\int _{\boldsymbol{r}}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\right).\end{eqnarray}$$
First, we calculate the local bracket with the local Hamiltonian functional (5.27):
 $$\begin{eqnarray}\displaystyle [{\mathcal{F}}_{0},{\mathcal{H}}_{0}]_{0} & = & \displaystyle \int _{\boldsymbol{z}_{0}}{\mathcal{J}}_{0}\,f_{0}\left\{\frac{1}{{\mathcal{J}}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}},K_{0}\right\}_{0}\nonumber\\ \displaystyle & & \displaystyle +\,4\unicode[STIX]{x03C0}c\int _{\boldsymbol{r}}\left[\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \frac{\boldsymbol{B}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}-\frac{\boldsymbol{E}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(0)}{\mathcal{F}}_{0}(\boldsymbol{r})\right)\right]\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}e\int _{\boldsymbol{z}_{0}}{\mathcal{J}}_{0}\,f_{0}\left(\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}\boldsymbol{\cdot }\{\boldsymbol{x},K_{0}\}_{0}-\frac{\boldsymbol{E}(\boldsymbol{x})}{4\unicode[STIX]{x03C0}}\boldsymbol{\cdot }\left\{\boldsymbol{x},\frac{1}{{\mathcal{J}}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}}\right\}_{0}\right),\end{eqnarray}$$
where we used (5.30). Next, after integrating by parts, we obtain
 $$\begin{eqnarray}\displaystyle [{\mathcal{F}}_{0},{\mathcal{H}}_{0}]_{0} & = & \displaystyle -\int _{\boldsymbol{z}_{0}}\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}f_{0}(\boldsymbol{z}_{0})}(\{\,f_{0},K_{0}\}_{0}+e\boldsymbol{E}(\boldsymbol{x})\boldsymbol{\cdot }\{\boldsymbol{x},f_{0}\}_{0}-c\unicode[STIX]{x1D735}\times \boldsymbol{E}(\boldsymbol{x})\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}f_{0})\nonumber\\ \displaystyle & & \displaystyle +\,\int _{\boldsymbol{r}}\left[\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }(c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}\,\boldsymbol{J}_{0})+\frac{\unicode[STIX]{x1D6FF}{\mathcal{F}}_{0}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\boldsymbol{\cdot }(-c\unicode[STIX]{x1D735}\times \boldsymbol{E})\right],\end{eqnarray}$$
from which we recover (5.33) when the local Vlasov–Maxwell equations (3.12) and (5.7)–(5.8) are substituted. Here, we used the relation
 $$\begin{eqnarray}-c\unicode[STIX]{x1D735}\times \boldsymbol{E}(\boldsymbol{x})\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}f_{0}=\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\boldsymbol{\cdot }\unicode[STIX]{x2202}_{\boldsymbol{B}}^{(0)}\,f_{0}\equiv \frac{\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\frac{\unicode[STIX]{x2202}f_{0}}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}}\end{eqnarray}$$
to recover the local Vlasov equation (5.23).
6 Dynamical reduction by phase-space transformation
We have seen in § 5 that, while the local Vlasov–Maxwell equations (3.12) and (5.7)–(5.8) possess a Hamiltonian structure defined in terms of the local Hamiltonian functional (5.27) and the local Vlasov–Maxwell bracket (5.32), the local Vlasov function
 $f_{0}$
evolves rapidly on a short gyromotion time scale that needs to be removed for practical (e.g. numerical) applications. The asymptotic elimination of the gyromotion time scale from the local Vlasov–Maxwell equations proceeds with the guiding-centre transformation
 $(\boldsymbol{x},p_{\Vert },\unicode[STIX]{x1D707},\unicode[STIX]{x1D701})\rightarrow (\overline{\boldsymbol{X}},\overline{p}_{\Vert },\overline{\unicode[STIX]{x1D707}},\overline{\unicode[STIX]{x1D701}})$
, where the guiding-centre Hamiltonian dynamics is now decoupled from the gyromotion time scale (Littlejohn Reference Littlejohn1983; Cary & Brizard Reference Cary and Brizard2009).
The guiding-centre phase-space transformation, however, is a non-local transformation involving displacements in local particle phase space that are expressed as asymptotic expansions in powers of an ordering parameter
 $\unicode[STIX]{x1D716}\ll 1$
. It is precisely this non-local feature of the guiding-centre transformation that allows the explicit introduction of guiding-centre polarization and magnetization effects in guiding-centre Vlasov–Maxwell theory (Brizard Reference Brizard2013; Tronko & Brizard Reference Tronko and Brizard2015). Since the guiding-centre transformation becomes the identity transformation in the limit
 $\unicode[STIX]{x1D716}\rightarrow 0$
, we now consider the transformation of the local Vlasov–Maxwell Hamiltonian structure under the action of a general near-identity phase-space transformation.
6.1 Near-identity phase-space transformation
The dynamical reduction of the Vlasov–Maxwell equations (3.10)–(3.14) is carried out by a near-identity phase-space transformation
 ${\mathcal{T}}^{\unicode[STIX]{x1D716}}:\boldsymbol{z}_{0}\rightarrow \overline{\boldsymbol{Z}}={\mathcal{T}}^{\unicode[STIX]{x1D716}}\boldsymbol{z}_{0}$
, where
 $\unicode[STIX]{x1D716}\ll 1$
denotes an ordering parameter associated with the dynamical reduction. The ordering parameter
 $\unicode[STIX]{x1D716}\equiv \unicode[STIX]{x1D714}\,\unicode[STIX]{x1D70F}$
is often chosen by comparing a short orbital time scale
 $\unicode[STIX]{x1D70F}$
with a long dynamical time scale
 $\unicode[STIX]{x1D714}^{-1}\gg \unicode[STIX]{x1D70F}$
of interest.
Each reduced phase-space coordinate
 $\overline{Z}^{\unicode[STIX]{x1D6FC}}$
is expressed as an asymptotic expansion in powers of
 $\unicode[STIX]{x1D716}$
involving components of the generating vector fields
 $(\unicode[STIX]{x1D60E}_{1},\unicode[STIX]{x1D60E}_{2},\ldots )$
on particle phase space:
 $$\begin{eqnarray}\overline{Z}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0};\unicode[STIX]{x1D716})=z_{0}^{\unicode[STIX]{x1D6FC}}+\unicode[STIX]{x1D716}G_{1}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0})+\unicode[STIX]{x1D716}^{2}\left(G_{2}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0})+\frac{1}{2}G_{1}^{\unicode[STIX]{x1D6FD}}(\boldsymbol{z}_{0})\frac{\unicode[STIX]{x2202}G_{1}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0})}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FD}}}\right)+\cdots ,\end{eqnarray}$$
where
 $\overline{Z}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0};\unicode[STIX]{x1D716}=0)=z_{0}^{\unicode[STIX]{x1D6FC}}$
(i.e. to lowest order, the reduced phase-space coordinates are local). We note that this transformation is invertible (since
 $\unicode[STIX]{x1D716}\ll 1$
), i.e.
 ${\mathcal{T}}^{-\unicode[STIX]{x1D716}}:\overline{\boldsymbol{Z}}\rightarrow \boldsymbol{z}_{0}={\mathcal{T}}^{-\unicode[STIX]{x1D716}}\overline{\boldsymbol{Z}}$
, where each particle coordinate
 $z_{0}^{\unicode[STIX]{x1D6FC}}$
is expressed as an asymptotic expansion in terms of the same generating vector fields
 $(\unicode[STIX]{x1D60E}_{1},\unicode[STIX]{x1D60E}_{2},\ldots )$
on reduced phase space.
The reduced Jacobian of the transformation (6.1) is constructed from the local Jacobian
 ${\mathcal{J}}_{0}=mB$
and the generating vector fields
 $(\unicode[STIX]{x1D60E}_{1},\unicode[STIX]{x1D60E}_{2},\ldots )$
as
 $$\begin{eqnarray}\overline{{\mathcal{J}}}\equiv {\mathcal{J}}_{0}-\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FC}}}\left[{\mathcal{J}}_{0}(\unicode[STIX]{x1D716}G_{1}^{\unicode[STIX]{x1D6FC}}+\unicode[STIX]{x1D716}^{2}G_{2}^{\unicode[STIX]{x1D6FC}}+\cdots )-\frac{\unicode[STIX]{x1D716}^{2}}{2}G_{1}^{\unicode[STIX]{x1D6FC}}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FD}}}({\mathcal{J}}_{0}G_{1}^{\unicode[STIX]{x1D6FD}}+\cdots )+\cdots \right].\end{eqnarray}$$
We note that, while the local particle phase-space coordinates
 $\boldsymbol{z}_{0}$
are independent of the electric field
 $\boldsymbol{E}$
, the reduced phase-space coordinates
 $\overline{\boldsymbol{Z}}(\boldsymbol{z}_{0};\boldsymbol{E},\boldsymbol{B})$
, and the reduced Jacobian (6.2), generally depend on the electromagnetic fields (but not the local Vlasov distribution
 $f_{0}$
).
6.2 Push-forward and pull-back operators
The reduction phase-space transformation (6.1) and its inverse induce transformations in function space (Littlejohn Reference Littlejohn1982), where the push-forward operator
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}:f_{0}\rightarrow \overline{f}=\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\,f_{0}\equiv f_{0}\circ {\mathcal{T}}^{-\unicode[STIX]{x1D716}}\end{eqnarray}$$
transforms a function
 $f_{0}$
on local particle phase space into a function
 $\overline{f}$
on reduced phase space, while the pull-back operator
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}:\overline{f}\rightarrow f_{0}=\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}\overline{f}\equiv \overline{f}\circ {\mathcal{T}}^{\unicode[STIX]{x1D716}}\end{eqnarray}$$
transforms a function
 $\overline{f}$
on reduced phase space into a function
 $f_{0}$
on local particle phase space. These induced transformations satisfy the scalar-covariance property, e.g.
 $f_{0}(\boldsymbol{z}_{0})=\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}\overline{f}(\boldsymbol{z}_{0})=\overline{f}({\mathcal{T}}^{\unicode[STIX]{x1D716}}\boldsymbol{z}_{0})=\overline{f}(\overline{\boldsymbol{Z}})$
. Moreover, the action of the push-forward operator on the phase-space infinitesimal volume yields the Jacobian transformation
 $\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}({\mathcal{J}}_{0}\,d^{6}z_{0})\equiv \overline{{\mathcal{J}}}\,d^{6}\overline{Z}$
, from which we obtain the Jacobian expansion (6.2). It is also useful to express the reduced Jacobian (6.2) as
 $$\begin{eqnarray}\overline{{\mathcal{J}}}\equiv (\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}{\mathcal{J}}_{0})\left[1-\unicode[STIX]{x1D716}\,\unicode[STIX]{x1D625}\cdot \unicode[STIX]{x1D60E}_{1}-\unicode[STIX]{x1D716}^{2}\unicode[STIX]{x1D625}\cdot \left(\unicode[STIX]{x1D60E}_{2}-{\textstyle \frac{1}{2}}\unicode[STIX]{x1D60E}_{1}\cdot \unicode[STIX]{x1D625}\unicode[STIX]{x1D60E}_{1}\right)+\cdots \right]\equiv (\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}{\mathcal{J}}_{0})\overline{{\mathcal{J}}}_{\unicode[STIX]{x1D716}},\end{eqnarray}$$
where
 $\overline{{\mathcal{J}}}_{\unicode[STIX]{x1D716}}$
is defined by the identity
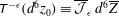 $\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}(d^{6}z_{0})\equiv \overline{{\mathcal{J}}}_{\unicode[STIX]{x1D716}}\,d^{6}\overline{Z}$
.
The reduced Poisson bracket
 $\{\,,\,\}_{\unicode[STIX]{x1D716}}$
is constructed from the local Poisson bracket
 $\{\,,\,\}_{0}$
in terms of the push-forward and pull-back operators:
 $$\begin{eqnarray}\displaystyle \{\overline{f},\overline{g}\}_{\unicode[STIX]{x1D716}}=\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}(\{\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}\overline{f},\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}\overline{g}\}_{0})\equiv \frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\overline{J}^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}\frac{\unicode[STIX]{x2202}\overline{g}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FD}}}\equiv \frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}(\overline{{\mathcal{J}}}\,\overline{f}\{\overline{Z}^{\unicode[STIX]{x1D6FC}},\overline{g}\}_{\unicode[STIX]{x1D716}}), & & \displaystyle\end{eqnarray}$$
where the divergence form uses the reduced Liouville property
 $\unicode[STIX]{x2202}(\overline{{\mathcal{J}}}\,\overline{J}^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}})/\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}\equiv 0$
.
Lastly, since the reduced Poisson matrix (with components
 $\overline{J}^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}\equiv \{\overline{Z}^{\unicode[STIX]{x1D6FC}},\overline{Z}^{\unicode[STIX]{x1D6FD}}\}_{\unicode[STIX]{x1D716}}$
) is defined as the inverse of the reduced Lagrange matrix (with components
 $\overline{\unicode[STIX]{x1D714}}_{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}}$
defined as the components of an exact two-form
 $\overline{\unicode[STIX]{x1D74E}}=\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\unicode[STIX]{x1D74E}_{0}$
in reduced phase space), the Jacobi property of the reduced Poisson bracket (6.6) is guaranteed by the identity
 $\unicode[STIX]{x1D625}\overline{\unicode[STIX]{x1D74E}}\equiv 0$
, i.e. the exterior derivative of an exact two-form
 $\overline{\unicode[STIX]{x1D74E}}\equiv \unicode[STIX]{x1D625}\overline{\unicode[STIX]{x1D6E4}}$
is automatically zero. A direct proof of the Jacobi identity for the reduced Poisson bracket (6.6) follows from the push-forward transformation
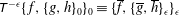 $\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\{\,f,\{g,h\}_{0}\}_{0}\equiv \{\overline{f},\{\overline{g},\overline{h}\}_{\unicode[STIX]{x1D716}}\}_{\unicode[STIX]{x1D716}}$
, where the definition (6.6) for the reduced Poisson bracket has been used twice. Hence, since the local Poisson bracket
 $\{\,,\,\}_{0}$
satisfies the Jacobi identity, then so does the reduced Poisson bracket (6.6).
6.3 Reduced phase-space displacements
We now define two complementary phase-space displacements in terms of push-forward and pull-back operators as follows. The local particle phase-space displacement
 $\unicode[STIX]{x1D6E5}^{\unicode[STIX]{x1D6FC}}$
is defined in terms of the pull-back operator as
 $$\begin{eqnarray}\unicode[STIX]{x1D6E5}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0})\equiv z_{0}^{\unicode[STIX]{x1D6FC}}-\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}=-\unicode[STIX]{x1D716}G_{1}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0})-\unicode[STIX]{x1D716}^{2}\left(G_{2}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0})+\frac{1}{2}G_{1}^{\unicode[STIX]{x1D6FD}}(\boldsymbol{z}_{0})\frac{\unicode[STIX]{x2202}G_{1}^{\unicode[STIX]{x1D6FC}}(\boldsymbol{z}_{0})}{\unicode[STIX]{x2202}z_{0}^{\unicode[STIX]{x1D6FD}}}\right)+\cdots ,\end{eqnarray}$$
while the reduced phase-space displacement
 $\overline{\unicode[STIX]{x1D6E5}}^{\unicode[STIX]{x1D6FC}}(\overline{\boldsymbol{Z}})\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}z_{0}^{\unicode[STIX]{x1D6FC}}-\overline{Z}^{\unicode[STIX]{x1D6FC}}$
is defined in terms of the push-forward operator as
 $\overline{\unicode[STIX]{x1D6E5}}^{\unicode[STIX]{x1D6FC}}\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\unicode[STIX]{x1D6E5}^{\unicode[STIX]{x1D6FC}}$
. Lastly, we note that the Jacobian
 $\overline{{\mathcal{J}}}_{\unicode[STIX]{x1D716}}$
defined in (6.5) can be expressed as
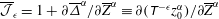 $\overline{{\mathcal{J}}}_{\unicode[STIX]{x1D716}}=1+\unicode[STIX]{x2202}\overline{\unicode[STIX]{x1D6E5}}^{\unicode[STIX]{x1D6FC}}/\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}\equiv \unicode[STIX]{x2202}(\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}z_{0}^{\unicode[STIX]{x1D6FC}})/\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}$
.
6.4 Reduced partial-time derivative
Since the phase-space transformations considered here are time-dependent transformations (which nonetheless preserve time), the operation of time differentiation does not commute with the push-forward and pull-back operators (6.3)–(6.4). Hence, we define the reduced partial-time derivative
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}}{\unicode[STIX]{x2202}t}\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\left(\frac{\unicode[STIX]{x2202}_{0}}{\unicode[STIX]{x2202}t}\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}\right)\equiv \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}},\end{eqnarray}$$
where, using (6.7), we obtain the definition
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\left[\frac{\unicode[STIX]{x2202}_{0}(\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x2202}t}\right]=\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\left(\frac{\unicode[STIX]{x2202}_{0}z_{0}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}-\frac{\unicode[STIX]{x2202}_{0}\unicode[STIX]{x1D6E5}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\right),\end{eqnarray}$$
and the partial-time derivative
 $\unicode[STIX]{x2202}\overline{{\mathcal{J}}}/\unicode[STIX]{x2202}t=-\unicode[STIX]{x2202}(\overline{{\mathcal{J}}}\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}/\unicode[STIX]{x2202}t)/\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}$
of the reduced Jacobian (6.5) follows from (4.12).
6.5 Reduced Hamiltonian dynamics
Next, we transform the non-canonical Hamilton equations (3.16) to obtain
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\equiv \frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}+\{\overline{Z}^{\unicode[STIX]{x1D6FC}},\overline{K}\}_{\unicode[STIX]{x1D716}}+e\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\boldsymbol{E}\boldsymbol{\cdot }\{\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\boldsymbol{x},\overline{Z}^{\unicode[STIX]{x1D6FC}}\}_{\unicode[STIX]{x1D716}}, & \displaystyle\end{eqnarray}$$
where the push forward of the kinetic energy is
 $$\begin{eqnarray}\overline{K}\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}K=K-\unicode[STIX]{x1D716}G_{1}^{\unicode[STIX]{x1D6FC}}\frac{\unicode[STIX]{x2202}K}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}-\unicode[STIX]{x1D716}^{2}\left[G_{2}^{\unicode[STIX]{x1D6FC}}\frac{\unicode[STIX]{x2202}K}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}-\frac{1}{2}G_{1}^{\unicode[STIX]{x1D6FD}}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FD}}}\left(G_{1}^{\unicode[STIX]{x1D6FC}}\frac{\unicode[STIX]{x2202}K}{\unicode[STIX]{x2202}z^{\unicode[STIX]{x1D6FC}}}\right)\right]+\cdots .\end{eqnarray}$$
The reduced Hamilton equations (6.10) satisfy the reduced Liouville theorem
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}\overline{{\mathcal{J}}}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\left(\overline{{\mathcal{J}}}\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\right)=\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\left[\overline{{\mathcal{J}}}\left(\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}-\frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\right)\right]\equiv 0,\end{eqnarray}$$
which follows from (6.10) and the reduced Liouville property
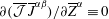 $\unicode[STIX]{x2202}(\overline{{\mathcal{J}}}\,\overline{J}^{\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D6FD}})/\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}\equiv 0$
.
7 Reduced Vlasov–Maxwell equations
The phase-space transformation (6.1), and its associated induced operators and meta-operators, allows us to derive the set of reduced Vlasov–Maxwell equations (Brizard Reference Brizard2008). Examples of such reduced Vlasov–Maxwell equations include the nonlinear gyrokinetic Vlasov–Maxwell equations (Brizard & Hahm Reference Brizard and Hahm2007; Krommes Reference Krommes2012), which yield important numerical advantages (Garbet et al. Reference Garbet, Idomura, Villard and Watanabe2010) in the computer simulations of the turbulent evolution of magnetized fusion plasmas.
7.1 Reduced Vlasov equation
The reduced Vlasov equation is defined as the push forward of the Vlasov equation (3.17):
 $$\begin{eqnarray}\displaystyle 0 & = & \displaystyle \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\left(\frac{\unicode[STIX]{x2202}_{0}\,f_{0}}{\unicode[STIX]{x2202}t}+\{\,f_{0},K_{0}\}_{0}+e\boldsymbol{E}\boldsymbol{\cdot }\{\boldsymbol{x},f_{0}\}_{0}\right)\nonumber\\ \displaystyle & \equiv & \displaystyle \frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{f}}{\unicode[STIX]{x2202}t}+\{\overline{f},\overline{K}\}_{\unicode[STIX]{x1D716}}+e\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\boldsymbol{E}\boldsymbol{\cdot }\{\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\boldsymbol{x},\overline{f}\}_{\unicode[STIX]{x1D716}},\end{eqnarray}$$
which, using (6.8), yields
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}t}=-\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\equiv -\left(\frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}+\{\overline{Z}^{\unicode[STIX]{x1D6FC}},\overline{K}\}_{\unicode[STIX]{x1D716}}+e\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\boldsymbol{E}\boldsymbol{\cdot }\{\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\boldsymbol{x},\overline{Z}^{\unicode[STIX]{x1D6FC}}\}_{\unicode[STIX]{x1D716}}\right)\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}},\end{eqnarray}$$
where the reduced Vlasov distribution
 $\overline{f}\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}f_{0}$
is defined as the push forward of the local particle Vlasov distribution
 $f_{0}$
. The reduced Vlasov equation (7.2) can also be written in divergence form as
 $$\begin{eqnarray}0=\frac{\unicode[STIX]{x2202}(\overline{{\mathcal{J}}}\,\overline{f})}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\left(\overline{{\mathcal{J}}}\,\overline{f}\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\text{d}t}\right),\end{eqnarray}$$
where we used the reduced Liouville theorem (6.12).
7.2 Reduced Maxwell equations
The reduced Maxwell equations are obtained from (5.8)–(5.9) by transforming the local current and charge densities by meta-push-forward operation:
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}\boldsymbol{E}(\boldsymbol{r})}{\unicode[STIX]{x2202}t}-c\unicode[STIX]{x1D735}\times \boldsymbol{B}(\boldsymbol{r}) & = & \displaystyle -4\unicode[STIX]{x03C0}e\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}(\overline{\boldsymbol{Z}})\overline{f}(\overline{\boldsymbol{Z}})\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}-\boldsymbol{r})\left(\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{\boldsymbol{X}}}{\text{d}t}+\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}}{\text{d}t}\right)\nonumber\\ \displaystyle & \equiv & \displaystyle -\,4\unicode[STIX]{x03C0}\mathbb{T}^{\unicode[STIX]{x1D716}}\boldsymbol{J}_{0}(\boldsymbol{r}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{E}(\boldsymbol{r})=4\unicode[STIX]{x03C0}e\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}(\overline{\boldsymbol{Z}})\overline{f}(\overline{\boldsymbol{Z}})\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}-\boldsymbol{r})\equiv 4\unicode[STIX]{x03C0}\mathbb{T}^{\unicode[STIX]{x1D716}}\unicode[STIX]{x1D71A}_{0}(\boldsymbol{r}), & \displaystyle\end{eqnarray}$$
while the remaining Maxwell equations (3.12) and (3.14) are unaffected by the dynamical reduction. In (7.4), the push forward of the particle velocity
 $\boldsymbol{v}=\text{d}\boldsymbol{x}/\text{d}t$
is introduced:
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\left(\frac{\text{d}_{0}\boldsymbol{x}}{\text{d}t}\right)=\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\left[\frac{\text{d}_{0}}{\text{d}t}\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}(\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}})\right]\equiv \frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{\boldsymbol{X}}}{\text{d}t}+\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}}{\text{d}t}\equiv \{\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}},\overline{K}\}_{\unicode[STIX]{x1D716}}.\end{eqnarray}$$
In addition, the reduced charge and current densities in (7.4)–(7.6) involve the reduced spatial displacement
 $\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\boldsymbol{x}-\overline{\boldsymbol{X}}$
, which plays an important part in the definition of the reduced polarization and magnetization (Brizard Reference Brizard2008) in the reduced Maxwell equations (7.4)–(7.5). The meta-push-forward of the (local) charge density in (7.5) yields the transformation
 $\mathbb{T}^{\unicode[STIX]{x1D716}}\unicode[STIX]{x1D71A}_{0}\equiv \unicode[STIX]{x1D71A}_{\unicode[STIX]{x1D716}}-\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{P}_{\unicode[STIX]{x1D716}}$
, where
 $\unicode[STIX]{x1D71A}_{\unicode[STIX]{x1D716}}$
denotes the reduced charge density, defined as
 $$\begin{eqnarray}\unicode[STIX]{x1D71A}_{\unicode[STIX]{x1D716}}(\boldsymbol{r})\equiv e\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}-\boldsymbol{r})\overline{{\mathcal{J}}}(\overline{\boldsymbol{Z}})\overline{f}(\overline{\boldsymbol{Z}}),\end{eqnarray}$$
and the reduced polarization charge density
 $\unicode[STIX]{x1D71A}_{\mathit{pol}}\equiv -\unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{P}_{\unicode[STIX]{x1D716}}$
is expressed in terms of the reduced polarization
 $\boldsymbol{P}_{\unicode[STIX]{x1D716}}$
, defined as (Brizard Reference Brizard2008, Reference Brizard2009)
 $$\begin{eqnarray}\boldsymbol{P}_{\unicode[STIX]{x1D716}}(\boldsymbol{r})\equiv e\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}-\boldsymbol{r})\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}\overline{{\mathcal{J}}}(\overline{\boldsymbol{Z}})\overline{f}(\overline{\boldsymbol{Z}})+\cdots .\end{eqnarray}$$
The meta-push-forward of the (local) current density in (7.4) yields the transformation
 $\mathbb{T}^{\unicode[STIX]{x1D716}}\boldsymbol{J}_{0}\equiv \boldsymbol{J}_{\unicode[STIX]{x1D716}}+\unicode[STIX]{x2202}\boldsymbol{P}_{\unicode[STIX]{x1D716}}/\unicode[STIX]{x2202}t+c\unicode[STIX]{x1D735}\times \boldsymbol{M}_{\unicode[STIX]{x1D716}}$
, where
 $\boldsymbol{J}_{\unicode[STIX]{x1D716}}$
denotes the reduced current density, defined as
 $$\begin{eqnarray}\boldsymbol{J}_{\unicode[STIX]{x1D716}}(\boldsymbol{r})\equiv e\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}-\boldsymbol{r})\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{\boldsymbol{X}}}{\text{d}t}\overline{{\mathcal{J}}}(\overline{\boldsymbol{Z}})\overline{f}(\overline{\boldsymbol{Z}}),\end{eqnarray}$$
 $\boldsymbol{J}_{pol}\equiv \unicode[STIX]{x2202}\boldsymbol{P}_{\unicode[STIX]{x1D716}}/\unicode[STIX]{x2202}t$
denotes the reduced polarization current density and the reduced magnetization current density
 ${\mathcal{J}}_{mag}\equiv c\unicode[STIX]{x1D735}\times \boldsymbol{M}_{\unicode[STIX]{x1D716}}$
is expressed in terms of the reduced magnetization
 $\boldsymbol{M}_{\unicode[STIX]{x1D716}}$
, defined as (Brizard Reference Brizard2008, Reference Brizard2009)
 $$\begin{eqnarray}\boldsymbol{M}_{\unicode[STIX]{x1D716}}(\boldsymbol{r})\equiv \frac{e}{c}\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}-\boldsymbol{r})\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}\times \left(\frac{1}{2}\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}}{\text{d}t}+\frac{\text{d}_{\unicode[STIX]{x1D716}}\overline{\boldsymbol{X}}}{\text{d}t}\right)\overline{{\mathcal{J}}}(\overline{\boldsymbol{Z}})\overline{f}(\overline{\boldsymbol{Z}})+\cdots .\end{eqnarray}$$
Hence, the reduced Maxwell equations (7.4)–(7.5) may also be written as
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}\boldsymbol{D}_{\unicode[STIX]{x1D716}}}{\unicode[STIX]{x2202}t}-c\unicode[STIX]{x1D735}\times \boldsymbol{H}_{\unicode[STIX]{x1D716}}=-4\unicode[STIX]{x03C0}\boldsymbol{J}_{\unicode[STIX]{x1D716}}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D735}\boldsymbol{\cdot }\boldsymbol{D}_{\unicode[STIX]{x1D716}}=4\unicode[STIX]{x03C0}\unicode[STIX]{x1D71A}_{\unicode[STIX]{x1D716}}, & \displaystyle\end{eqnarray}$$
where the reduced electromagnetic fields are
 $\boldsymbol{D}_{\unicode[STIX]{x1D716}}\equiv \boldsymbol{E}+4\unicode[STIX]{x03C0}\boldsymbol{P}_{\unicode[STIX]{x1D716}}$
and
 $\boldsymbol{H}_{\unicode[STIX]{x1D716}}\equiv \boldsymbol{B}-4\unicode[STIX]{x03C0}\boldsymbol{M}_{\unicode[STIX]{x1D716}}$
.
8 Lie-transform lift of the Vlasov–Maxwell bracket
In complete analogy with the definition of the reduced Poisson bracket (6.6), we now define the reduced Vlasov–Maxwell bracket
 $[\,,\,]_{\unicode[STIX]{x1D716}}$
:
 $$\begin{eqnarray}[\overline{{\mathcal{F}}},\overline{{\mathcal{G}}}]_{\unicode[STIX]{x1D716}}\equiv \mathbb{T}^{\unicode[STIX]{x1D716}}([(\mathbb{T}^{-\unicode[STIX]{x1D716}}\overline{{\mathcal{F}}}),(\mathbb{T}^{-\unicode[STIX]{x1D716}}\overline{{\mathcal{G}}})]_{0}),\end{eqnarray}$$
which acts on functionals of the reduced Vlasov distribution
 $\overline{f}$
and the electromagnetic fields
 $(\boldsymbol{E},\boldsymbol{B})$
. The reduced bracket (8.1) satisfies the standard antisymmetry and Leibniz properties. By introducing the double functional-bracket transformation
 $$\begin{eqnarray}\displaystyle \mathbb{T}^{\unicode[STIX]{x1D716}}([{\mathcal{F}}_{0},[{\mathcal{G}}_{0},{\mathcal{H}}_{0}]_{0}]_{0}) & = & \displaystyle \mathbb{T}^{\unicode[STIX]{x1D716}}([\mathbb{T}^{-\unicode[STIX]{x1D716}}(\mathbb{T}^{\unicode[STIX]{x1D716}}{\mathcal{F}}_{0}),\mathbb{T}^{-\unicode[STIX]{x1D716}}(\mathbb{T}^{\unicode[STIX]{x1D716}}[\mathbb{T}^{-\unicode[STIX]{x1D716}}(\mathbb{T}^{\unicode[STIX]{x1D716}}{\mathcal{G}}_{0}),\mathbb{T}^{-\unicode[STIX]{x1D716}}(\mathbb{T}^{\unicode[STIX]{x1D716}}{\mathcal{H}}_{0})]_{0})]_{0})\nonumber\\ \displaystyle & = & \displaystyle [\mathbb{T}^{\unicode[STIX]{x1D716}}{\mathcal{F}}_{0},[\mathbb{T}^{\unicode[STIX]{x1D716}}{\mathcal{G}}_{0},\mathbb{T}^{\unicode[STIX]{x1D716}}{\mathcal{H}}_{0}]_{\unicode[STIX]{x1D716}}]_{\unicode[STIX]{x1D716}}\equiv [\overline{{\mathcal{F}}},[\overline{{\mathcal{G}}},\overline{{\mathcal{H}}}]_{\unicode[STIX]{x1D716}}]_{\unicode[STIX]{x1D716}},\end{eqnarray}$$
we note that the reduced Vlasov–Maxwell bracket
 $[\,,\,]_{\unicode[STIX]{x1D716}}$
satisfies the Jacobi property:
 $$\begin{eqnarray}[\overline{{\mathcal{F}}},[\overline{{\mathcal{G}}},\overline{{\mathcal{K}}}]_{\unicode[STIX]{x1D716}}]_{\unicode[STIX]{x1D716}}+[\overline{{\mathcal{G}}},[\overline{{\mathcal{K}}},\overline{{\mathcal{F}}}]_{\unicode[STIX]{x1D716}}]_{\unicode[STIX]{x1D716}}+[\overline{{\mathcal{K}}},[\overline{{\mathcal{F}}},\overline{{\mathcal{G}}}]_{\unicode[STIX]{x1D716}}]_{\unicode[STIX]{x1D716}}=0,\end{eqnarray}$$
since the local Vlasov–Maxwell bracket
 $[\,,\,]_{0}$
satisfies the Jacobi property.
8.1 Reduced Vlasov–Maxwell bracket
In what follows, we combine the local phase-space transformation
 ${\mathcal{T}}_{0}$
and the near-identity phase-space transformation
 ${\mathcal{T}}^{\unicode[STIX]{x1D716}}$
into a single phase-space transformation
 ${\mathcal{T}}_{\unicode[STIX]{x1D716}}\equiv {\mathcal{T}}^{\unicode[STIX]{x1D716}}\circ {\mathcal{T}}_{0}$
. Hence, we introduce the operators
 $\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}\equiv \unicode[STIX]{x1D61B}_{0}\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}$
and
 $\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\equiv \unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\unicode[STIX]{x1D61B}_{0}^{-1}$
as well as the meta-operators
 $\mathbb{T}_{\unicode[STIX]{x1D716}}\equiv \mathbb{T}^{\unicode[STIX]{x1D716}}\mathbb{T}_{0}$
and
 $\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\equiv \mathbb{T}_{0}^{-1}\mathbb{T}^{-\unicode[STIX]{x1D716}}$
.
The reduced Vlasov–Maxwell bracket (4.39) now becomes
 $$\begin{eqnarray}\displaystyle [\overline{{\mathcal{F}}},\overline{{\mathcal{G}}}]_{\unicode[STIX]{x1D716}} & \equiv & \displaystyle \mathbb{T}_{\unicode[STIX]{x1D716}}([\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}},\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{G}}}])\nonumber\\ \displaystyle & = & \displaystyle \int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\left\{\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}},\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{G}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\right\}_{\unicode[STIX]{x1D716}}\nonumber\\ \displaystyle & & \displaystyle +\,4\unicode[STIX]{x03C0}c\int _{\boldsymbol{r}}\left[\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{G}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{G}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\right]\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}e\int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\boldsymbol{\cdot }\left[\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}-\boldsymbol{r})\left\{\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}},\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{G}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\right\}_{\unicode[STIX]{x1D716}}\right]\nonumber\\ \displaystyle & & \displaystyle +\,4\unicode[STIX]{x03C0}e\int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{G}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\boldsymbol{\cdot }\left[\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}-\boldsymbol{r})\left\{\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}},\frac{1}{\overline{{\mathcal{J}}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\right\}_{\unicode[STIX]{x1D716}}\right],\qquad\end{eqnarray}$$
where the reduced functional derivatives are defined as
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})} & = & \displaystyle \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}-\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\left[\frac{\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\right]\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}(\overline{\boldsymbol{Z}})}\nonumber\\ \displaystyle & \equiv & \displaystyle \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}^{(\unicode[STIX]{x1D716})}\overline{{\mathcal{F}}}(\boldsymbol{r}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})} & = & \displaystyle \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\left[\frac{\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\right]\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}(\overline{\boldsymbol{Z}})}\nonumber\\ \displaystyle & \equiv & \displaystyle \frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(\unicode[STIX]{x1D716})}\overline{{\mathcal{F}}}(\boldsymbol{r}),\end{eqnarray}$$
with
 $$\begin{eqnarray}\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})}\right)\equiv \int _{\boldsymbol{r}}\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}-\boldsymbol{r})\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}.\end{eqnarray}$$
We will now show that the reduced Vlasov–Maxwell bracket (8.4) can be used to derive the reduced Vlasov equation (7.2) and the reduced Maxwell equations (3.12) and (7.4).
8.2 Hamiltonian formulation of the reduced Vlasov–Maxwell equations
By inserting the reduced Hamiltonian functional
 $$\begin{eqnarray}\overline{{\mathcal{H}}}[\overline{f},\boldsymbol{E},\boldsymbol{B}]\equiv \mathbb{T}^{\unicode[STIX]{x1D716}}{\mathcal{H}}_{0}=\frac{1}{8\unicode[STIX]{x03C0}}\int _{\boldsymbol{r}}(|\boldsymbol{E}|^{2}+|\boldsymbol{B}|^{2})+\int _{\overline{\boldsymbol{Z}}}\overline{{\mathcal{J}}}\,\overline{f}\,\overline{K}(\boldsymbol{E},\boldsymbol{B})\end{eqnarray}$$
in the reduced Vlasov–Maxwell bracket (8.4), and integrating by parts, we obtain
 $$\begin{eqnarray}\displaystyle [\overline{{\mathcal{F}}},\overline{{\mathcal{H}}}]_{\unicode[STIX]{x1D716}} & = & \displaystyle -\int _{\overline{\boldsymbol{Z}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\left[\{\overline{f},\overline{K}\}_{\unicode[STIX]{x1D716}}+4\unicode[STIX]{x03C0}e\left(\int _{\boldsymbol{r}}\unicode[STIX]{x1D6FF}^{3}(\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}-\boldsymbol{r})\{\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}},\overline{f}\}_{\unicode[STIX]{x1D716}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{H}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\right)\right]\nonumber\\ \displaystyle & & \displaystyle +\,4\unicode[STIX]{x03C0}\int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\boldsymbol{\cdot }\left[c\unicode[STIX]{x1D735}\times \left(\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{H}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\right)-\mathbb{T}_{\unicode[STIX]{x1D716}}\boldsymbol{J}(\boldsymbol{r})\right]\nonumber\\ \displaystyle & & \displaystyle -\,4\unicode[STIX]{x03C0}c\int _{\boldsymbol{r}}\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{F}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\boldsymbol{\cdot }\unicode[STIX]{x1D735}\times \left(\frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{H}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\right),\end{eqnarray}$$
where
 $\overline{K}\equiv \overline{H}-e\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\unicode[STIX]{x1D6F7}$
, and the meta push forward
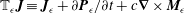 $\mathbb{T}_{\unicode[STIX]{x1D716}}\boldsymbol{J}\equiv \boldsymbol{J}_{\unicode[STIX]{x1D716}}+\unicode[STIX]{x2202}\boldsymbol{P}_{\unicode[STIX]{x1D716}}/\unicode[STIX]{x2202}t+c\unicode[STIX]{x1D735}\times \boldsymbol{M}_{\unicode[STIX]{x1D716}}$
of the particle-current density is given by (7.4), with
 $\unicode[STIX]{x1D6FF}\overline{{\mathcal{H}}}/\unicode[STIX]{x1D6FF}\overline{f}=\overline{{\mathcal{J}}}\,\overline{K}$
and
 $\{\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}},\overline{K}\}_{\unicode[STIX]{x1D716}}\equiv \text{d}_{\unicode[STIX]{x1D716}}\overline{\boldsymbol{X}}/\text{d}t+\text{d}_{\unicode[STIX]{x1D716}}\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}/\text{d}t$
. In addition, the functional derivatives
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{H}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}=\left[\frac{\boldsymbol{E}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}+\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\right)\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\overline{{\mathcal{J}}}\,\overline{K}\right]-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}^{(\unicode[STIX]{x1D716})}\overline{{\mathcal{H}}}\equiv \frac{\boldsymbol{E}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{H}}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}=\left[\frac{\boldsymbol{B}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}+\int _{\overline{\boldsymbol{Z}}}\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\left(\frac{\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\right)\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\overline{{\mathcal{J}}}\,\overline{K}\right]-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(\unicode[STIX]{x1D716})}\overline{{\mathcal{H}}}\equiv \frac{\boldsymbol{B}(\boldsymbol{r})}{4\unicode[STIX]{x03C0}}, & \displaystyle\end{eqnarray}$$
are used in the Maxwell sub-bracket while
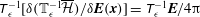 $\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}[\unicode[STIX]{x1D6FF}(\mathbb{T}_{\unicode[STIX]{x1D716}}^{-1}\overline{{\mathcal{H}}})/\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{x})]=\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\boldsymbol{E}/4\unicode[STIX]{x03C0}$
is used in the interaction sub-bracket.
By combining these expressions, we find
 $$\begin{eqnarray}\displaystyle [\overline{{\mathcal{F}}},\overline{{\mathcal{H}}}]_{\unicode[STIX]{x1D716}} & = & \displaystyle -\int _{\overline{\boldsymbol{Z}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}[\{\overline{f},\overline{K}\}_{\unicode[STIX]{x1D716}}+e\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\boldsymbol{E}\boldsymbol{\cdot }\{\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}},\overline{f}\}_{\unicode[STIX]{x1D716}}]\nonumber\\ \displaystyle & & \displaystyle +\,\int _{\boldsymbol{r}}\left[\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}-\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}^{(\unicode[STIX]{x1D716})}\overline{{\mathcal{F}}}\right)\boldsymbol{\cdot }(c\unicode[STIX]{x1D735}\times \boldsymbol{B}-4\unicode[STIX]{x03C0}\mathbb{T}_{\unicode[STIX]{x1D716}}\boldsymbol{J})-\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{ B}}-\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(\unicode[STIX]{x1D716})}\overline{{\mathcal{F}}}\right)\boldsymbol{\cdot }(c\unicode[STIX]{x1D735}\times \boldsymbol{E})\right]\nonumber\\ \displaystyle & \equiv & \displaystyle \int _{\overline{\boldsymbol{Z}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}t}+\int _{\boldsymbol{r}}\left(\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{E}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}+\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\boldsymbol{B}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\right),\end{eqnarray}$$
where we used the reduced Maxwell equations (3.12) and (7.4). We also substituted the reduced Vlasov equation (7.2):
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}t}=-\{\overline{f},\overline{K}\}_{\unicode[STIX]{x1D716}}-e\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\boldsymbol{E}\boldsymbol{\cdot }\{\overline{\boldsymbol{X}}+\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}},\overline{f}\}_{\unicode[STIX]{x1D716}}-\frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}},\end{eqnarray}$$
where
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}} & \equiv & \displaystyle \unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}^{-1}\left[\frac{\unicode[STIX]{x2202}(\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x2202}t}\right]\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\nonumber\\ \displaystyle & = & \displaystyle \int _{\boldsymbol{r}}\left[\frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}\boldsymbol{\cdot }\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\left(\frac{\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x1D6FF}\boldsymbol{E}(\boldsymbol{r})}\right)\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}+\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\boldsymbol{\cdot }\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}\left(\frac{\unicode[STIX]{x1D6FF}(\unicode[STIX]{x1D61B}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}})}{\unicode[STIX]{x1D6FF}\boldsymbol{B}(\boldsymbol{r})}\right)\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\right],\qquad\end{eqnarray}$$
so that we made use of the identity in (8.9):
 $$\begin{eqnarray}\int _{\boldsymbol{r}}\left(\unicode[STIX]{x1D6E5}_{\boldsymbol{E}}^{(\unicode[STIX]{x1D716})}\overline{{\mathcal{F}}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{E}}{\unicode[STIX]{x2202}t}+\unicode[STIX]{x1D6E5}_{\boldsymbol{B}}^{(\unicode[STIX]{x1D716})}\overline{{\mathcal{F}}}\boldsymbol{\cdot }\frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}\right)\equiv \int _{\overline{\boldsymbol{Z}}}\frac{\unicode[STIX]{x2202}_{\unicode[STIX]{x1D716}}\overline{Z}^{\unicode[STIX]{x1D6FC}}}{\unicode[STIX]{x2202}t}\frac{\unicode[STIX]{x2202}\overline{f}}{\unicode[STIX]{x2202}\overline{Z}^{\unicode[STIX]{x1D6FC}}}\frac{\unicode[STIX]{x1D6FF}\overline{{\mathcal{F}}}}{\unicode[STIX]{x1D6FF}\overline{f}}.\end{eqnarray}$$
Hence, the reduced Vlasov–Maxwell equations can be expressed as (8.12) in terms of the reduced Hamiltonian functional (8.8) and the reduced Vlasov–Maxwell bracket (8.4).
9 Summary
The reduced Vlasov–Maxwell bracket (8.4) has been derived from the local Vlasov–Maxwell bracket (5.32) by Lie-transform methods based on the dynamical reduction associated with a near-identity phase-space transformation
 ${\mathcal{T}}^{\unicode[STIX]{x1D716}}$
and its inverse
 ${\mathcal{T}}^{-\unicode[STIX]{x1D716}}$
. These phase-space transformations induce transformations on functions denoted by the push-forward operator
 $\unicode[STIX]{x1D61B}^{-\unicode[STIX]{x1D716}}f_{0}\equiv f_{0}\circ {\mathcal{T}}^{-\unicode[STIX]{x1D716}}$
and the pull-back operator
 $\unicode[STIX]{x1D61B}^{\unicode[STIX]{x1D716}}\overline{f}\equiv \overline{f}\circ {\mathcal{T}}^{\unicode[STIX]{x1D716}}$
. These pull-back and push-forward operators, in turn, induce transformations on functionals denoted by the meta-push-forward operator
 $\mathbb{T}^{\unicode[STIX]{x1D716}}$
and meta-pull-back operator
 $\mathbb{T}^{-\unicode[STIX]{x1D716}}$
, which guarantee the Jacobi property (8.3) for the reduced Vlasov–Maxwell bracket.
In future work, we will explore the Hamiltonian formulation of the guiding-centre Vlasov–Maxwell equations, following recent works by Burby et al. (Reference Burby, Brizard, Morrison and Qin2015a
) and Burby, Brizard & Qin (Reference Burby, Brizard and Qin2015b
), as well as the variational formulations of guiding-centre Vlasov–Maxwell theory derived by Brizard & Tronci (Reference Brizard and Tronci2016). In particular, we will focus on investigating how the Hamiltonian properties of the reduced Vlasov–Maxwell bracket (8.4) survive (i) the closure problem: the process of truncation of the guiding-centre Vlasov–Maxwell bracket at a finite order in
 $\unicode[STIX]{x1D716}$
(so far expressions have been derived at all orders in
 $\unicode[STIX]{x1D716}$
) and (ii) the averaging problem: the process by which the gyroangle is eliminated from the guiding-centre Vlasov–Maxwell bracket (since guiding-centre Vlasov–Maxwell equations do not involve the fast gyromotion time scale). In (8.4)–(8.6), since the terms
 $\overline{\unicode[STIX]{x1D746}}_{\unicode[STIX]{x1D716}}$
and
 $\unicode[STIX]{x1D6E5}_{\boldsymbol{E},\boldsymbol{B}}^{(\unicode[STIX]{x1D716})}$
are expected to contain gyroangle-independent and gyroangle-dependent contributions resulting from the guiding-centre transformation, the gyroangle averaging and closure problems of the guiding-centre Vlasov–Maxwell bracket will be addressed explicitly.
Acknowledgements
Work by A.J.B., P.J.M. and J.W.B. were supported by US Department of Energy contracts No. DE-SC0006721 (A.J.B.) and DE-SC0014032 (A.J.B.), No. DE-FG02-04ER-54742 (P.J.M.), and No. DE-FG02- 86ER53223 (J.W.B.). Also, A.J.B. and P.J.M. have greatly benefited from the kind hospitality of the Centre de Physique Théorique where this work was started. Work by M.V. was supported as part of the A*MIDEX project (ANR-11-IDEX-0001-02), funded by the ‘Investissements d’Avenir’, French Government program, managed by the French National Research Agency (ANR).


