



1 Introduction
In recent years, several varieties of autophoretic colloidal particles have been fabricated and studied in the laboratory (Paxton et al.
Reference Paxton, Kistler, Olmeda, Sen, St. Angelo, Cao, Mallouk, Lammert and Crespi2004; Gibbs & Zhao Reference Gibbs and Zhao2009; Ebbens & Howse Reference Ebbens and Howse2010; Jiang, Yoshinaga & Sano Reference Jiang, Yoshinaga and Sano2010; Wang et al.
Reference Wang, Duan, Ahmed, Mallouk and Sen2013). Under common approximations (Anderson Reference Anderson1989) including thinness of the interfacial layer near the particle surface
 $S$
, the small Reynolds number self-propulsion of such a particle is understood in terms of a slip velocity
 $\boldsymbol{v}_{sl}=\unicode[STIX]{x1D707}\unicode[STIX]{x1D735}_{S}\unicode[STIX]{x1D6F7}$
generated across the interfacial layer by the tangential gradient
 $\unicode[STIX]{x1D735}_{S}\unicode[STIX]{x1D6F7}$
of a field
 $\unicode[STIX]{x1D6F7}$
– electric potential (electrophoresis), chemical concentration (diffusiophoresis, electrophoresis) or temperature (thermophoresis) – obeying the Laplace equation in the outer region when the Péclet number is small. Although the slip mobility
 $\unicode[STIX]{x1D707}$
can vary with position, we take it uniform, as is commonly done. From
 $\boldsymbol{v}_{sl}$
, the particle velocity can be found via a (Lorentz) reciprocity relation if the surface traction generated by translating an inert particle in a quiescent fluid is known. Compared to the classical subject (Anderson Reference Anderson1989) of phoresis of passive particles driven by an externally imposed field
 $\unicode[STIX]{x1D6F7}$
, the distinctive feature of autophoresis is that
 $\unicode[STIX]{x1D6F7}$
is ultimately due to a flux density
 $J$
at the particle surface of chemical species, heat, etc. which is proportional to the normal derivative of
 $\unicode[STIX]{x1D6F7}$
and often more accessible than
 $\unicode[STIX]{x1D735}_{S}\unicode[STIX]{x1D6F7}$
both experimentally and theoretically. Thus, formulas relating particle velocity and angular velocity directly to the flux are highly desirable. Previous formulas of this sort (Golestanian, Liverpool & Ajdari Reference Golestanian, Liverpool and Ajdari2007; Popescu et al.
Reference Popescu, Dietrich, Tasinkevych and Ralston2010; Yariv Reference Yariv2011; Nourhani et al.
Reference Nourhani, Lammert, Crespi and Borhan2015b
; Schnitzer & Yariv Reference Schnitzer and Yariv2015) have been limited to bodies of axisymmetric shape with an axisymmetric flux distribution. (Equivalently, only the component of velocity along the symmetry axis was found.) Except for the work (Yariv Reference Yariv2011; Schnitzer & Yariv Reference Schnitzer and Yariv2015) on slender bodies, these results have mostly taken the form of expansions in special functions, which are not always transparent, and can make the identification of asymptotic limits difficult, as in Popescu et al. (Reference Popescu, Dietrich, Tasinkevych and Ralston2010). We prove (equation (2.20)) that, within the simple autophoretic model described above, for arbitrary particle shape, the hydrodynamic force and torque generated by the slip velocity is exactly the same as would be generated by a hypothetical radial velocity proportional to the flux density! Thus, the latter can be substituted for the former in the reciprocity method velocity formulas, obviating the need to calculate
 $\unicode[STIX]{x1D6F7}$
. Using this result, we easily derive simple integral kernels transforming arbitrary flux distributions into the complete rotational and translational velocities of both spheroids and slender bodies, recovering the results of Nourhani & Lammert (Reference Nourhani and Lammert2016) for the former and Schnitzer & Yariv (Reference Schnitzer and Yariv2015) for the latter. Simple integral kernels such as those derived here are very valuable for completely mapping out motor performance over well-defined design spaces.
The body of the paper is structured as follows. In § 2, we present the general theory, reviewing (§ 2.2) the use of Lorentz reciprocity for Stokes flow and demonstrating (§ 2.3) the central claim that the hydrodynamic force and torque generated by
 $\boldsymbol{v}_{sl}$
are exactly the same as are generated by
 $(\unicode[STIX]{x1D707}/{\mathcal{D}})J\boldsymbol{n}$
, with
 ${\mathcal{D}}$
a transport coefficient appearing in the Neumann boundary condition
 $J=-{\mathcal{D}}\unicode[STIX]{x2202}\unicode[STIX]{x1D6F7}/\unicode[STIX]{x2202}n$
. In § 3, this result is applied to shape-axisymmetric bodies, for which a simple formulation in terms of one-dimensional integrals is worked out using symmetry. Symmetry considerations also show that an autophoretic particle cannot rotate about its symmetry axis, absent symmetry breaking by the environment, or possibly an inhomogeneous slip mobility
 $\unicode[STIX]{x1D707}$
. Methods based on reciprocity require the surface traction on a rigidly moving inert particle as input. Using literature results for that, the scheme is applied to spheroids, both prolate and oblate (§ 3.2), as well as slender bodies (§ 3.3) to derive, in just a few lines, complete and simple integral expressions for the translational (3.17), (3.24) and rotational (3.20), (3.28) velocities. The reader interested only in the results can skip straight to those, after a glance at § 2.1 and the preamble to § 3, as well as (3.7) and (3.8). In the concluding section, we observe that the velocity formula for a slender body suggests that non-convex shapes can propel in a direction counter to naive expectations.
2 General theory
This section commences with a more precise definition of our model, followed by a review of the use of the Lorentz reciprocity theorem for Stokes flow, then the main result embodied in (2.20), which rests on the key observation (2.14).
2.1 Model
Our model consists of a boundary value problem for a fluid-filled, unbounded domain
 $O$
with boundary
 $\unicode[STIX]{x2202}O=S$
. The surface
 $S$
– meant to represent the ‘outer edge’ of the infinitely thin interfacial layer around an autophoretic particle – is taken to be a smooth closed compact two-manifold embedded in
 $\mathbb{R}^{3}$
. The particle is the source of a field
 $\unicode[STIX]{x1D6F7}$
, obeying
 $\unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D6F7}=0$
in
 $O$
and with boundary conditions
 $$\begin{eqnarray}\displaystyle & \displaystyle \left.\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6F7}}{\unicode[STIX]{x2202}n}\right|_{S}=-\frac{J}{{\mathcal{D}}}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \unicode[STIX]{x1D6F7}\rightarrow \text{const.}\text{ as }|x|\rightarrow \infty . & \displaystyle\end{eqnarray}$$
 $\unicode[STIX]{x1D6F7}$
. The flux density
 $J$
is taken as given in this model rather than determined from more basic data such as chemical kinetics (Sabass & Seifert Reference Sabass and Seifert2012; Nourhani, Crespi & Lammert Reference Nourhani, Crespi and Lammert2015a
).
Since we are interested in a low Reynolds number flow, the fluid in
 $O$
is taken to be governed by the Stokes system
 $$\begin{eqnarray}\unicode[STIX]{x1D702}\unicode[STIX]{x1D6FB}^{2}\boldsymbol{v}=\unicode[STIX]{x1D735}p;\quad \text{div}\;\boldsymbol{v}=0.\end{eqnarray}$$
The boundary conditions on the fluid velocity are
 $$\begin{eqnarray}\displaystyle & \boldsymbol{v}|_{S}=\boldsymbol{v}_{sl}=\unicode[STIX]{x1D707}\unicode[STIX]{x1D735}_{S}\unicode[STIX]{x1D6F7}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \boldsymbol{v}\rightarrow 0\quad \text{as}~|x|\rightarrow \infty . & \displaystyle\end{eqnarray}$$
 $S$
, implies that the velocity is
 $O(1/|x|)$
and the stress
 $O(1/|x|^{2})$
as
 $|x|\rightarrow \infty$
.
2.2 Lorentz reciprocity for Stokes flows
The stress tensor for a Stokes field (
 $\boldsymbol{v}$
,
 $p$
pair) is given by (superscript ‘
 $\dagger$
’ denotes transpose)
 $$\begin{eqnarray}\unicode[STIX]{x1D64F}=-p\unicode[STIX]{x1D644}+\unicode[STIX]{x1D702}[\unicode[STIX]{x1D735}\boldsymbol{v}+(\unicode[STIX]{x1D735}\boldsymbol{v})^{\dagger }].\end{eqnarray}$$
An arbitrary pair of Stokes flows
 $\boldsymbol{v}$
and
 $\boldsymbol{u}$
in a bounded volume
 ${\mathcal{V}}$
with smooth boundary
 $\unicode[STIX]{x2202}{\mathcal{V}}$
satisfies the well-known reciprocity relation (Brenner Reference Brenner1964b
; Happel & Brenner Reference Happel and Brenner1983; Pozrikidis Reference Pozrikidis1992; Kim & Karrila Reference Kim and Karrila2005) (‘Lorentz reciprocal theorem’)
 $$\begin{eqnarray}\int _{\unicode[STIX]{x2202}{\mathcal{V}}}\boldsymbol{v}\boldsymbol{\cdot }\boldsymbol{f}[\boldsymbol{u}]\,\text{d}S=\int _{\unicode[STIX]{x2202}{\mathcal{V}}}\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{f}[\boldsymbol{v}]\,\text{d}S,\end{eqnarray}$$
where
 $\boldsymbol{f}[\boldsymbol{v}]:=\boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D64F}|_{\unicode[STIX]{x2202}{\mathcal{V}}}$
is the hydrodynamic surface force density arising from the flow
 $\boldsymbol{v}$
(acting from the side pointed to by
 $\boldsymbol{n}$
). In the context of our problem, the reciprocity relation can be applied to the part of
 $O$
inside a sphere of large volume
 $R$
. But, because of the fall off implied by boundary condition (2.3b
), the integral over that sphere vanishes as
 $R\rightarrow \infty$
, leaving simply
 $$\begin{eqnarray}\int _{S}\boldsymbol{v}\boldsymbol{\cdot }\boldsymbol{f}[\boldsymbol{u}]\,\text{d}S=\int _{S}\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{f}[\boldsymbol{v}]\,\text{d}S.\end{eqnarray}$$
Now, with
 $\boldsymbol{n}$
pointing into
 $O$
, the net hydrodynamic force
 $\boldsymbol{F}$
and torque
 $\boldsymbol{L}$
acting across
 $S$
from the outside by the flow
 $\boldsymbol{u}$
are given by
 $$\begin{eqnarray}\boldsymbol{F}[\boldsymbol{u}]=\int _{S}\boldsymbol{f}[\boldsymbol{u}]\,\text{d}S;\quad \boldsymbol{L}[\boldsymbol{u}]=\int _{S}\boldsymbol{r}\times \boldsymbol{f}[\boldsymbol{u}]\,\text{d}S.\end{eqnarray}$$
In the special case that
 $\boldsymbol{u}=\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}$
reduces to a rigid-body motion
 $$\begin{eqnarray}\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}|_{S}=\boldsymbol{U}+\unicode[STIX]{x1D734}\times \boldsymbol{r}\end{eqnarray}$$
on
 $S$
, the corresponding surface force density must, by linearity, take the form
 $$\begin{eqnarray}\boldsymbol{f}[\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}](\boldsymbol{x})=\unicode[STIX]{x1D640}(\boldsymbol{x})\boldsymbol{\cdot }\boldsymbol{U}+\unicode[STIX]{x1D642}(\boldsymbol{x})\boldsymbol{\cdot }\unicode[STIX]{x1D734}\quad (\boldsymbol{x}\in S),\end{eqnarray}$$
for tensor functions
 $\unicode[STIX]{x1D640}(\boldsymbol{x})$
and
 $\unicode[STIX]{x1D642}(\boldsymbol{x})$
. Inserting these expressions into the reciprocity relation (2.6) and pulling the arbitrary constants
 $\boldsymbol{U}$
and
 $\unicode[STIX]{x1D734}$
out of the integrals yields
 $$\begin{eqnarray}\boldsymbol{F}[\boldsymbol{v}]=\int _{S}\unicode[STIX]{x1D640}^{\dagger }\boldsymbol{\cdot }\boldsymbol{v}\,\text{d}S;\quad \boldsymbol{L}[\boldsymbol{v}]=\int _{S}\unicode[STIX]{x1D642}^{\dagger }\boldsymbol{\cdot }\boldsymbol{v}\,\text{d}S.\end{eqnarray}$$
In particular, if
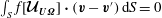 $\int _{S}f[\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}]\boldsymbol{\cdot }(\boldsymbol{v}-\boldsymbol{v}^{\prime })\,\text{d}S=0$
for every
 $\boldsymbol{U}$
and
 $\unicode[STIX]{x1D734}$
, then
 $\boldsymbol{F}[\boldsymbol{v}]=\boldsymbol{F}[\boldsymbol{v}^{\prime }]$
and
 $\boldsymbol{L}[\boldsymbol{v}]=\boldsymbol{L}[\boldsymbol{v}^{\prime }]$
.
Returning to the problem of the motion of an autophoretic particle, we decompose the fluid velocity at the outer edge of the interfacial layer into the slip velocity
 $\boldsymbol{v}_{sl}$
and an unknown rigid-body motion:
 $$\begin{eqnarray}\boldsymbol{v}=\boldsymbol{v}_{sl}+\boldsymbol{U}_{p}+(\unicode[STIX]{x1D734}_{p}\times \boldsymbol{r})\quad \text{on }S.\end{eqnarray}$$
Assuming we know
 $\unicode[STIX]{x1D640}$
and
 $\unicode[STIX]{x1D642}$
, equation (2.10) can be used to determine
 $\boldsymbol{U}_{p}$
and
 $\unicode[STIX]{x1D734}_{p}$
. They are whatever is required to provide a force and torque cancelling
 $\boldsymbol{F}[\boldsymbol{v}_{sl}]$
and
 $\boldsymbol{L}[\boldsymbol{v}_{sl}]$
, namely,
 $$\begin{eqnarray}\left(\begin{array}{@{}c@{}}\boldsymbol{U}_{p}\\ \unicode[STIX]{x1D734}_{p}\end{array}\right)=-\left(\begin{array}{@{}cc@{}}\unicode[STIX]{x1D63C} & \unicode[STIX]{x1D63D}\\ \unicode[STIX]{x1D63D}^{\dagger } & \unicode[STIX]{x1D63E}\end{array}\right)^{-1}\left(\begin{array}{@{}c@{}}\boldsymbol{F}[\boldsymbol{v}_{sl}]\\ \boldsymbol{ L}[\boldsymbol{v}_{sl}]\end{array}\right).\end{eqnarray}$$
The block matrix here is the symmetric hydrodynamic resistance matrix (Kim & Karrila Reference Kim and Karrila2005), with blocks given by
 $$\begin{eqnarray}\unicode[STIX]{x1D63C}=\int _{S}\unicode[STIX]{x1D640}^{\dagger }\,\text{d}S;\quad \unicode[STIX]{x1D63D}=\int _{S}-\unicode[STIX]{x1D640}^{\dagger }\times \boldsymbol{r}\,\text{d}S;\quad \unicode[STIX]{x1D63E}=\int _{S}-\unicode[STIX]{x1D642}^{\dagger }\times \boldsymbol{r}\,\text{d}S.\end{eqnarray}$$
2.3 A shortcut
Now, our slip velocity is
 $\boldsymbol{v}_{sl}=\unicode[STIX]{x1D707}\unicode[STIX]{x1D735}_{S}\unicode[STIX]{x1D6F7}$
. If we had
 $\unicode[STIX]{x1D6F7}$
in hand, (2.7), (2.12) and (2.13) could be used to find the translational and rotational velocities of the autophoretic particle. However, the source flux density
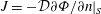 $J=-{\mathcal{D}}\unicode[STIX]{x2202}\unicode[STIX]{x1D6F7}/\unicode[STIX]{x2202}n|_{S}$
is usually much more accessible, so we would like an expression directly in terms of
 $J$
, thus avoiding the need to solve for
 $\unicode[STIX]{x1D6F7}$
. The key to this is the identity
 $$\begin{eqnarray}\int _{S}\boldsymbol{f}[\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}]\boldsymbol{\cdot }\unicode[STIX]{x1D735}\unicode[STIX]{x1D6F7}\,\text{d}S=0,\end{eqnarray}$$
where
 $\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}$
goes to zero at infinity (2.3b
) and reduces to
 $\boldsymbol{U}+\unicode[STIX]{x1D74E}\boldsymbol{\cdot }\boldsymbol{r}$
on
 $S$
(
 $\unicode[STIX]{x1D714}_{ik}=\sum _{j}\unicode[STIX]{x1D716}_{ijk}\unicode[STIX]{x1D6FA}_{j}$
), while
 $\unicode[STIX]{x1D6F7}$
obeys the Laplace equation and the boundary conditions (2.1). To see this, note first that
 $\unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D6F7}=0$
guarantees that
 $(\boldsymbol{v}=\unicode[STIX]{x1D735}\unicode[STIX]{x1D6F7},p=0)$
is a legitimate Stokes flow with stress tensor
 $\unicode[STIX]{x1D64F}=2\unicode[STIX]{x1D702}\unicode[STIX]{x1D735}\unicode[STIX]{x1D735}\unicode[STIX]{x1D6F7}$
. As
 $r\rightarrow \infty$
,
 $\boldsymbol{v}=O(1/r^{2})$
and
 $\unicode[STIX]{x1D64F}=O(1/r^{3})$
. The reciprocity relation (2.6) is therefore applicable, and yields
 $$\begin{eqnarray}\int _{S}\boldsymbol{f}[\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}]\boldsymbol{\cdot }\unicode[STIX]{x1D735}\unicode[STIX]{x1D6F7}\,\text{d}S=\int _{S}\boldsymbol{f}[\unicode[STIX]{x1D735}\unicode[STIX]{x1D6F7}]\boldsymbol{\cdot }\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}\,\text{d}S=\int _{S}\boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D64F}\boldsymbol{\cdot }\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}\,\text{d}S.\end{eqnarray}$$
Insert the explicit form of
 $\boldsymbol{{\mathcal{U}}}_{\boldsymbol{U}\unicode[STIX]{x1D734}}$
on
 $S$
to rewrite this as
 $$\begin{eqnarray}\cdots =\boldsymbol{U}\boldsymbol{\cdot }\int _{S}\boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D64F}\,\text{d}S+\int _{S}\boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D64F}\boldsymbol{\cdot }\unicode[STIX]{x1D74E}\boldsymbol{\cdot }\boldsymbol{r}\,\text{d}S.\end{eqnarray}$$
Now, apply the divergence theorem to obtain
 $$\begin{eqnarray}\cdots =\boldsymbol{U}\boldsymbol{\cdot }\int _{O}\unicode[STIX]{x1D735}\boldsymbol{\cdot }\unicode[STIX]{x1D64F}\,\text{d}V+\int _{O}\unicode[STIX]{x1D735}\boldsymbol{\cdot }(\unicode[STIX]{x1D64F}\boldsymbol{\cdot }\unicode[STIX]{x1D74E}\boldsymbol{\cdot }\boldsymbol{r})\,\text{d}V.\end{eqnarray}$$
This step is somewhat delicate. Since the integral of
 $\boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D64F}$
over a sphere of large radius
 $R$
is
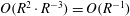 $O(R^{2}\cdot R^{-3})=O(R^{-1})$
, the conversion of the first integral is legitimate. For the second one, note that
 $$\begin{eqnarray}\int _{S_{R}}\boldsymbol{n}\boldsymbol{\cdot }(\unicode[STIX]{x1D735}\unicode[STIX]{x1D735}\unicode[STIX]{x1D6F7})\boldsymbol{\cdot }\unicode[STIX]{x1D74E}\boldsymbol{\cdot }\boldsymbol{r}\,\text{d}S=\unicode[STIX]{x1D714}_{jk}\int _{S_{R}}Rn^{i}n^{k}\unicode[STIX]{x2202}_{i}\unicode[STIX]{x2202}_{j}\unicode[STIX]{x1D6F7}\,\text{d}S.\end{eqnarray}$$
The monopole term
 $1/r$
does not contribute because
 $\unicode[STIX]{x1D714}_{jk}$
is antisymmetric. (Ultimately, this vanishing comes down to the monopole field and the rigid rotation field belonging to different representations of
 $SO(3)$
.) Moving to the
 $O(1/r^{2})$
dipole contribution shows the integral to be
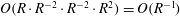 $O(R\cdot R^{-2}\cdot R^{-2}\cdot R^{2})=O(R^{-1})$
. Thus, equation (2.17) is justified, and the first integral there is even zero, because
 $\unicode[STIX]{x1D735}\boldsymbol{\cdot }\unicode[STIX]{x1D64F}=0$
. Finally, since
 $\unicode[STIX]{x1D74E}$
is constant, while
 $\unicode[STIX]{x1D64F}$
is divergence free,
 $$\begin{eqnarray}\unicode[STIX]{x1D735}\boldsymbol{\cdot }(\unicode[STIX]{x1D64F}\boldsymbol{\cdot }\unicode[STIX]{x1D74E}\boldsymbol{\cdot }\boldsymbol{r})=\text{Tr}\,(\unicode[STIX]{x1D64F}\boldsymbol{\cdot }\unicode[STIX]{x1D74E}).\end{eqnarray}$$
However,
 $\unicode[STIX]{x1D64F}$
is symmetric,
 $\unicode[STIX]{x1D74E}$
anti-symmetric, so this is zero, and the second integral in (2.17) with it. Equation (2.14) is therefore proved.
The velocity field
 $\unicode[STIX]{x1D735}\unicode[STIX]{x1D6F7}$
in the preceding is a purely auxiliary entity, introduced for the purpose of obtaining (2.14), which can now be used to obtain the result we really need. Since
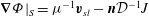 $\unicode[STIX]{x1D735}\unicode[STIX]{x1D6F7}|_{S}=\unicode[STIX]{x1D707}^{-1}\boldsymbol{v}_{sl}-\boldsymbol{n}{\mathcal{D}}^{-1}J$
, the comment immediately following (2.10) implies that
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \boldsymbol{F}[\boldsymbol{v}_{sl}]=\frac{\unicode[STIX]{x1D707}}{{\mathcal{D}}}\boldsymbol{F}[J\boldsymbol{n}],\\ \displaystyle \boldsymbol{L}[\boldsymbol{v}_{sl}]=\frac{\unicode[STIX]{x1D707}}{{\mathcal{D}}}\boldsymbol{L}[J\boldsymbol{n}].\end{array}\right\} & & \displaystyle\end{eqnarray}$$
We could hardly be more fortunate. We wished to work with
 $J$
instead of
 $\boldsymbol{v}_{sl}$
and these equations grant permission to do so in nearly the most straightforward sense imaginable: simply replace
 $\boldsymbol{v}_{sl}$
in (2.12) with
 $(\unicode[STIX]{x1D707}/{\mathcal{D}})J\boldsymbol{n}$
. That gives us
 $$\begin{eqnarray}\left(\begin{array}{@{}c@{}}\boldsymbol{U}_{p}\\ \unicode[STIX]{x1D734}_{p}\end{array}\right)=-\frac{\unicode[STIX]{x1D707}}{{\mathcal{D}}}\left(\begin{array}{@{}cc@{}}\unicode[STIX]{x1D63C} & \unicode[STIX]{x1D63D}\\ \unicode[STIX]{x1D63D}^{\dagger } & \unicode[STIX]{x1D63E}\end{array}\right)^{-1}\int \left(\begin{array}{@{}c@{}}\boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D640}\\ \boldsymbol{ n}\boldsymbol{\cdot }\unicode[STIX]{x1D642}\end{array}\right)J\,\text{d}S.\end{eqnarray}$$
Perhaps the most important advantage of this is that both
 $\boldsymbol{U}_{p}$
and
 $\unicode[STIX]{x1D734}_{p}$
are accessible for arbitrary
 $J$
, not just the axisymmetric flux distributions heretofore treated. To use this reciprocity-based method, whether directly with
 $J$
or with
 $\boldsymbol{v}_{sl}$
, requires knowledge of the tensor functions
 $\unicode[STIX]{x1D640}$
and
 $\unicode[STIX]{x1D642}$
that come from solution of an auxiliary problem involving an inert particle rotated and translated in an otherwise quiescent fluid. The next section takes up that issue.
3 Axisymmetric bodies
Now we apply the general theory of the previous section to shape-axisymmetric bodies (no symmetry assumed of the flux density). The surface
 $S$
of such a body is given in cylindrical coordinates
 $(z,\unicode[STIX]{x1D70C},\unicode[STIX]{x1D719})$
by
 $$\begin{eqnarray}S:\quad -1\leqslant z\leqslant 1;\quad 0\leqslant \unicode[STIX]{x1D719}<2\unicode[STIX]{x03C0};\quad \unicode[STIX]{x1D70C}=R(z).\end{eqnarray}$$
By choice of units, the length of the body is 2, leaving the radius function
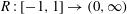 $R:[-1,1]\rightarrow (0,\infty )$
as the only variable element (undercuts are not allowed). In many cases, as for the spheroids and slender bodies treated below, one wants a family of surfaces obtained by varying a scaling parameter
 $\unicode[STIX]{x1D705}$
:
 $$\begin{eqnarray}R(z)=\unicode[STIX]{x1D705}R^{\ast }(z).\end{eqnarray}$$
In § 3.1, we develop some general formulae for the rotational and translational velocities of axisymmetric bodies. They are applied in §§ 3.2 and 3.3 to the spheroid family and slender bodies, respectively, using literature results for the surface traction on an inert translating and rotating particle.
3.1 Symmetry and reduction to one dimension
Now we use
 $C_{\infty }$
rotational symmetry about the
 $z$
-axis and the attendant mirror symmetries to simplify the general problem of determining translational and rotational velocities. For axisymmetric bodies generally, the translational and rotational problems can be decoupled. All the required integrals reduce to one-dimensional integrals over
 $z$
involving a handful of functions characterizing the hydrodynamic properties of
 $S$
and only three Fourier components of
 $J$
(with respect to
 $\unicode[STIX]{x1D719}$
).
Decoupling of the translational and rotational problems is accomplished by finding a point about which pure rotations entail no net force. With respect to that centre of resistance, the off-diagonal blocks
 $\unicode[STIX]{x1D63D}$
,
 $\unicode[STIX]{x1D63D}^{\dagger }$
of the resistance matrix (2.13) vanish. Recall that, under reflection in a plane, the perpendicular components of ordinary vectors, notably velocity and force, change sign while in-plane components are unchanged. On the other hand, components of pseudo-vectors such as angular velocity and torque behave in the opposite way. Consider rotation about the
 $z$
-axis. By rotational symmetry, the resulting force must be along
 $z$
. Consideration of a mirror plane containing the
 $z$
-axis shows that it is actually zero. Now consider rotation
 $\unicode[STIX]{x1D734}$
about a point
 $p$
on the
 $z$
-axis. Consideration of a plane containing
 $\boldsymbol{e}_{z}$
and
 $\unicode[STIX]{x1D734}$
shows that
 $\boldsymbol{F}\propto \boldsymbol{e}_{z}\times \unicode[STIX]{x1D734}$
, with a proportionality that changes sign as
 $p$
moves from
 $z\ll 0$
to
 $0\ll z$
. By continuity, there is an intermediate point where it vanishes, which is the sought-after centre of resistance. In case the body has a reflection plane perpendicular to the
 $z$
axis, as for a spheroid, the centre of resistance is necessarily in that plane. We show later that for a slender body, the centre of resistance is asymptotically at the midpoint of the body’s length. From now on, we implicitly work with the origin at the centre of resistance. The block
 $\unicode[STIX]{x1D63C}$
is independent of origin, and therefore can be calculated without knowing where the centre is.
The tensor functions
 $\unicode[STIX]{x1D640}$
and
 $\unicode[STIX]{x1D642}$
can be expanded on the dyadic products
 $\unicode[STIX]{x1D617}_{\!ij}:=\boldsymbol{e}_{i}\boldsymbol{e}_{j}$
made from
 $\boldsymbol{e}_{z}$
,
 $\boldsymbol{e}_{\unicode[STIX]{x1D70C}}$
and
 $\boldsymbol{e}_{\unicode[STIX]{x1D719}}$
, with coefficients which are functions solely of
 $z$
. However, reflection symmetry about planes containing the
 $z$
-axis forces some coefficients to be zero. Since
 $\unicode[STIX]{x1D640}$
transforms vectors to vectors, it cannot couple components in the
 $\boldsymbol{e}_{z}\wedge \boldsymbol{e}_{\unicode[STIX]{x1D70C}}$
plane to those perpendicular to it, namely
 $\boldsymbol{e}_{\unicode[STIX]{x1D719}}$
.
 $\unicode[STIX]{x1D642}$
, on the other hand, couples (angular velocity) pseudo-vectors to (force) vectors. Thus, we can write the expansions
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\unicode[STIX]{x1D640}={\mathcal{E}}_{zz}\unicode[STIX]{x1D64B}_{\!z}+{\mathcal{E}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D70C}}\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D70C}}+{\mathcal{E}}_{\unicode[STIX]{x1D719}\unicode[STIX]{x1D719}}\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D719}}+{\mathcal{E}}_{z\unicode[STIX]{x1D70C}}\unicode[STIX]{x1D64B}_{\!z\unicode[STIX]{x1D70C}}+{\mathcal{E}}_{\unicode[STIX]{x1D70C}z}\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D70C}z},\\ \unicode[STIX]{x1D642}={\mathcal{G}}_{z\unicode[STIX]{x1D719}}\unicode[STIX]{x1D64B}_{\!z\unicode[STIX]{x1D719}}+{\mathcal{G}}_{\unicode[STIX]{x1D719}z}\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D719}z}+{\mathcal{G}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}}\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}}+{\mathcal{G}}_{\unicode[STIX]{x1D719}\unicode[STIX]{x1D70C}}\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D719}\unicode[STIX]{x1D70C}},\end{array}\right\} & & \displaystyle\end{eqnarray}$$
where
 $\unicode[STIX]{x1D64B}_{\!z}$
abbreviates the orthogonal projector
 $\unicode[STIX]{x1D64B}_{\!zz}$
and similarly for
 $\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D70C}}$
and
 $\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D719}}$
.
Having eliminated
 $\unicode[STIX]{x1D63D}$
by choice of origin, symmetry implies that the remaining blocks of the resistance matrix take the forms
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\unicode[STIX]{x1D63C}={\mathcal{A}}_{z}\unicode[STIX]{x1D64B}_{\!z}+{\mathcal{A}}_{\bot }\unicode[STIX]{x1D64B}_{\!\bot },\\ \unicode[STIX]{x1D63E}={\mathcal{C}}_{z}\unicode[STIX]{x1D64B}_{\!z}+{\mathcal{C}}_{\bot }\unicode[STIX]{x1D64B}_{\!\bot }.\end{array}\right\} & & \displaystyle\end{eqnarray}$$
Substituting (3.3) into equations (2.13) and using the fact that the angular averages of
 $\boldsymbol{e}_{\unicode[STIX]{x1D70C}}$
and
 $\boldsymbol{e}_{\unicode[STIX]{x1D719}}$
are zero, while those of
 $2\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D70C}}$
and
 $2\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D719}}$
are
 $\unicode[STIX]{x1D64B}_{\!\bot }:=\unicode[STIX]{x1D644}-\unicode[STIX]{x1D64B}_{\!z}$
yields expressions
 $$\begin{eqnarray}{\mathcal{A}}_{z}=\int {\mathcal{E}}_{zz}2\unicode[STIX]{x03C0}R\,\text{d}\ell ,\quad {\mathcal{A}}_{\bot }=\frac{1}{2}\int ({\mathcal{E}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D70C}}+{\mathcal{E}}_{\unicode[STIX]{x1D719}\unicode[STIX]{x1D719}})2\unicode[STIX]{x03C0}R\,\text{d}\ell ,\end{eqnarray}$$
 $$\begin{eqnarray}{\mathcal{C}}_{z}=\int R{\mathcal{G}}_{\unicode[STIX]{x1D719}z}2\unicode[STIX]{x03C0}R\,\text{d}\ell ,\quad {\mathcal{C}}_{\bot }=\frac{1}{2}\int [z({\mathcal{G}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}}-{\mathcal{G}}_{\unicode[STIX]{x1D719}\unicode[STIX]{x1D70C}})-R{\mathcal{G}}_{z\unicode[STIX]{x1D719}}]2\unicode[STIX]{x03C0}R\,\text{d}\ell .\end{eqnarray}$$
Here, we have written the surface area element as
 $$\begin{eqnarray}\text{d}S=\text{d}\unicode[STIX]{x1D719}R\,\text{d}\ell ,\end{eqnarray}$$
where
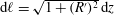 $\text{d}\ell =\sqrt{1+(R^{\prime })^{2}}\,\text{d}z$
is the differential arc length along a constant-
 $\unicode[STIX]{x1D719}$
longitudinal section.
To use (2.21) for the rotational and translational velocities, we need to put
 $\int \boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D640}J\,\text{d}S$
and
 $\int \boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D642}J\,\text{d}S$
in the same format. To do that, Fourier expand the flux density
 $J(z,\unicode[STIX]{x1D719})$
with respect to
 $\unicode[STIX]{x1D719}$
, obtaining
 $$\begin{eqnarray}J(z,\unicode[STIX]{x1D719})=J_{0}(z)+J_{x}(z)\cos \unicode[STIX]{x1D719}+J_{y}(z)\sin \unicode[STIX]{x1D719}+\cdots \,.\end{eqnarray}$$
Only the explicit terms here are needed, expressed more conveniently as
 $J_{0}$
and the vector defined by
 $$\begin{eqnarray}\boldsymbol{J}_{\bot }(z):=J_{x}(z)\boldsymbol{e}_{x}+J_{y}(z)\boldsymbol{e}_{y}.\end{eqnarray}$$
This is because those are all that occur in the angular averages at fixed
 $z$
,
 $\langle J\rangle _{\unicode[STIX]{x1D719}}=J_{0}(z)$
,
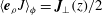 $\langle \boldsymbol{e}_{\unicode[STIX]{x1D70C}}J\rangle _{\unicode[STIX]{x1D719}}=\boldsymbol{J}_{\bot }(z)/2$
,
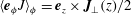 $\langle \boldsymbol{e}_{\unicode[STIX]{x1D719}}J\rangle _{\unicode[STIX]{x1D719}}=\boldsymbol{e}_{z}\times \boldsymbol{J}_{\bot }(z)/2$
. Unlike in (3.5), we will take
 $z$
as the integration variable rather than
 $\ell$
, using
 $$\begin{eqnarray}\frac{\text{d}\ell }{\text{d}z}\boldsymbol{n}=-R^{\prime }\boldsymbol{e}_{z}+\boldsymbol{e}_{\unicode[STIX]{x1D70C}}.\end{eqnarray}$$
With the expansions (3.3), we find
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \frac{\text{d}\ell }{\text{d}z}\boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D640}=(-R^{\prime }{\mathcal{E}}_{zz}+{\mathcal{E}}_{\unicode[STIX]{x1D70C}z})\boldsymbol{e}_{z}+(-R^{\prime }{\mathcal{E}}_{z\unicode[STIX]{x1D70C}}++{\mathcal{E}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D70C}})\boldsymbol{e}_{\unicode[STIX]{x1D70C}},\\ \displaystyle \frac{\text{d}\ell }{\text{d}z}\boldsymbol{n}\boldsymbol{\cdot }\unicode[STIX]{x1D642}=(-R^{\prime }{\mathcal{G}}_{z\unicode[STIX]{x1D719}}+{\mathcal{G}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}})\boldsymbol{e}_{\unicode[STIX]{x1D719}}.\end{array}\right\} & & \displaystyle\end{eqnarray}$$
Insertion into (2.10) produces
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \frac{{\mathcal{D}}}{\unicode[STIX]{x1D707}}\boldsymbol{F}[\boldsymbol{n}J]=2\unicode[STIX]{x03C0}\int \left[({\mathcal{E}}_{\unicode[STIX]{x1D70C}z}-R^{\prime }{\mathcal{E}}_{zz})J_{0}\boldsymbol{e}_{z}+({\mathcal{E}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D70C}}-R^{\prime }{\mathcal{E}}_{z\unicode[STIX]{x1D70C}})\frac{\boldsymbol{J}_{\bot }}{2}\right]R\,\text{d}z\\ \displaystyle \frac{{\mathcal{D}}}{\unicode[STIX]{x1D707}}\boldsymbol{L}[\boldsymbol{n}J]=2\unicode[STIX]{x03C0}\boldsymbol{e}_{z}\times \int \frac{\boldsymbol{J}_{\bot }}{2}(-R^{\prime }{\mathcal{G}}_{z\unicode[STIX]{x1D719}}+{\mathcal{G}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}})R\,\text{d}z.\end{array}\right\} & & \displaystyle\end{eqnarray}$$
Combining this with (3.5), we finally obtain
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{{\mathcal{D}}}{\unicode[STIX]{x1D707}}\boldsymbol{U}_{p}=\frac{2\unicode[STIX]{x03C0}}{{\mathcal{A}}_{z}}\boldsymbol{e}_{z}\int (R^{\prime }{\mathcal{E}}_{zz}-{\mathcal{E}}_{\unicode[STIX]{x1D70C}z})J_{0}R\,\text{d}z+\frac{\unicode[STIX]{x03C0}}{{\mathcal{A}}_{\bot }}\int \boldsymbol{J}_{\bot }(R^{\prime }{\mathcal{E}}_{z\unicode[STIX]{x1D70C}}-{\mathcal{E}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D70C}})R\,\text{d}z, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{{\mathcal{D}}}{\unicode[STIX]{x1D707}}\unicode[STIX]{x1D734}_{p}=\frac{\unicode[STIX]{x03C0}}{{\mathcal{C}}_{\bot }}\boldsymbol{e}_{z}\times \int \boldsymbol{J}_{\bot }(R^{\prime }{\mathcal{G}}_{z\unicode[STIX]{x1D719}}-{\mathcal{G}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}})R\,\text{d}z. & \displaystyle\end{eqnarray}$$
An interesting consequence of (3.12b
) is that the particle cannot generate an angular velocity about its shape symmetry axis
 $\boldsymbol{e}_{z}$
. Actually, this is implied by symmetry and linearity, and is therefore independent of the thin boundary layer approximation. By linearity, if it were possible for the particle to rotate about
 $\boldsymbol{e}_{z}$
, some single Fourier component of
 $J$
would suffice, say
 $J\propto \cos (m\unicode[STIX]{x1D719})$
. But,
 $\boldsymbol{e}_{x}\wedge \boldsymbol{e}_{z}$
is a mirror plane for the surface decorated with the scalar field
 $J$
or the vector field
 $\boldsymbol{n}J$
, while the proposed pseudo-vector
 $\unicode[STIX]{x1D6FA}$
lies within this plane. An autophoretic sphere, therefore, ought not to rotate at all, regardless of
 $J$
. If it does, it must be due to a symmetry-breaking environment or non-uniform slip mobility
 $\unicode[STIX]{x1D707}$
.
3.2 The spheroid family
The spheroidal family of surfaces is generated by the standard radius
 $$\begin{eqnarray}R^{\ast }(z)=\sqrt{1-z^{2}},\quad 0<\unicode[STIX]{x1D705}.\end{eqnarray}$$
If
 $\unicode[STIX]{x1D705}<1$
(
 $\unicode[STIX]{x1D705}=1$
,
 $\unicode[STIX]{x1D705}>1$
), this describes a prolate spheroid with eccentricity
 $\unicode[STIX]{x1D700}=\sqrt{1-\unicode[STIX]{x1D705}^{2}}$
(sphere, oblate spheroid with eccentricity
 $\sqrt{1-\unicode[STIX]{x1D705}^{-2}}$
). For a spheroid (Brenner Reference Brenner1964b
; Fair & Anderson Reference Fair and Anderson1989),
 $$\begin{eqnarray}\unicode[STIX]{x1D640}=(\boldsymbol{n}\boldsymbol{\cdot }\boldsymbol{r})(\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D64B}_{\!z}+\unicode[STIX]{x1D6FD}\unicode[STIX]{x1D64B}_{\!\bot }),\end{eqnarray}$$
with
 $\boldsymbol{r}$
denoting the position relative to the centre of the body and
 $\unicode[STIX]{x1D6FC}$
,
 $\unicode[STIX]{x1D6FD}$
are constants (values of which will not be needed). In terms of components (3.3),
 $$\begin{eqnarray}{\mathcal{E}}_{zz}=\unicode[STIX]{x1D6FC}(\boldsymbol{n}\boldsymbol{\cdot }\boldsymbol{r}),\quad {\mathcal{E}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D70C}}={\mathcal{E}}_{\unicode[STIX]{x1D719}\unicode[STIX]{x1D719}}=\unicode[STIX]{x1D6FD}(\boldsymbol{n}\boldsymbol{\cdot }\boldsymbol{r}).\end{eqnarray}$$
From (3.13), simple manipulations lead to
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \frac{\text{d}R^{\ast }}{\text{d}z}=-\frac{z}{R^{\ast }},\\ \displaystyle \frac{\text{d}\ell }{\text{d}z}=\frac{1}{R^{\ast }}\sqrt{1+(\unicode[STIX]{x1D705}^{2}-1)z^{2}},\\ \displaystyle \boldsymbol{n}=\frac{\unicode[STIX]{x1D705}z\boldsymbol{e}_{z}+\sqrt{1-z^{2}}\boldsymbol{e}_{\unicode[STIX]{x1D70C}}}{\sqrt{1+(\unicode[STIX]{x1D705}^{2}-1)z^{2}}},\\ \displaystyle (\boldsymbol{n}\boldsymbol{\cdot }\boldsymbol{r})R\,\text{d}\ell =\unicode[STIX]{x1D705}^{2}\,\text{d}z.\end{array}\right\} & & \displaystyle\end{eqnarray}$$
Insertion into (3.12a ) gives the particle velocity
 $$\begin{eqnarray}\displaystyle \boldsymbol{U}_{p} & = & \displaystyle \frac{\unicode[STIX]{x1D707}}{{\mathcal{D}}}\int \left(\unicode[STIX]{x1D705}\frac{\text{d}R^{\ast }}{\text{d}z}J_{0}(z)\boldsymbol{e}_{z}-\frac{1}{2}\boldsymbol{J}_{\bot }(z)\right)\frac{\text{d}z}{\text{d}\ell }\frac{\text{d}z}{2}\nonumber\\ \displaystyle & = & \displaystyle -\frac{\unicode[STIX]{x1D707}}{{\mathcal{D}}}\int \left(\unicode[STIX]{x1D705}zJ_{0}(z)\boldsymbol{e}_{z}+\frac{R^{\ast }}{2}\boldsymbol{J}_{\bot }(z)\right)\frac{\text{d}z}{2\sqrt{1+(\unicode[STIX]{x1D705}^{2}-1)z^{2}}}.\end{eqnarray}$$
The second form here is more practical; the first facilitates comparison with the slender-body result (3.24). The case of fully axisymmetric
 $J$
has been studied (Popescu et al.
Reference Popescu, Dietrich, Tasinkevych and Ralston2010; Nourhani et al.
Reference Nourhani, Lammert, Crespi and Borhan2015c
), but the complete formula (3.17) does not seem to be in the literature.
In a similarly automatic way, the angular velocity is computed using (Fair & Anderson Reference Fair and Anderson1989)
 $$\begin{eqnarray}\unicode[STIX]{x1D642}=(\boldsymbol{n}\boldsymbol{\cdot }\boldsymbol{r})\{-\unicode[STIX]{x1D6FC}R\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D719}z}+\unicode[STIX]{x1D6FD}[z(\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D719}\unicode[STIX]{x1D70C}}-\unicode[STIX]{x1D64B}_{\!\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}})+R\unicode[STIX]{x1D64B}_{\!z\unicode[STIX]{x1D719}}]\},\end{eqnarray}$$
with
 $\unicode[STIX]{x1D6FC}$
,
 $\unicode[STIX]{x1D6FD}$
(possibly new) constants. Only the three coefficient functions
 $$\begin{eqnarray}{\mathcal{G}}_{\unicode[STIX]{x1D719}\unicode[STIX]{x1D70C}}=-{\mathcal{G}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}}=\unicode[STIX]{x1D6FD}z(\boldsymbol{n}\boldsymbol{\cdot }\boldsymbol{r}),\quad {\mathcal{G}}_{z\unicode[STIX]{x1D719}}=\unicode[STIX]{x1D6FD}R(\boldsymbol{n}\boldsymbol{\cdot }\boldsymbol{r})\end{eqnarray}$$
are actually needed. Plugging into (3.12b ) yields
 $$\begin{eqnarray}\unicode[STIX]{x1D734}_{p}=-\frac{3}{4}\frac{\unicode[STIX]{x1D707}}{{\mathcal{D}}}\left(\frac{1-\unicode[STIX]{x1D705}^{2}}{1+\unicode[STIX]{x1D705}^{2}}\right)\boldsymbol{e}_{z}\times \int \boldsymbol{J}_{\bot }(z)\frac{\text{d}z}{\text{d}\ell }z\,\text{d}z.\end{eqnarray}$$
Note that, in accordance with earlier discussion, this vanishes for
 $\unicode[STIX]{x1D705}=1$
(sphere).
3.3 Slender bodies
In this section we develop an asymptotic theory which imposes no particular form for
 $R^{\ast }$
, but applies, a priori, only in the limit of small
 $\unicode[STIX]{x1D705}$
. A radius function of a slender-body family is
 $$\begin{eqnarray}R^{\ast }=O(1),\quad 0<\unicode[STIX]{x1D705}\ll 1.\end{eqnarray}$$
From the general theory of slender bodies in Stokes flow (Batchelor Reference Batchelor1970; Cox Reference Cox1970; Keller & Rubinow Reference Keller and Rubinow1976), we know that to leading order in an expansion in
 $1/\ln \unicode[STIX]{x1D705}$
,
 $$\begin{eqnarray}\unicode[STIX]{x1D640}\sim R^{-1}(\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D64B}_{\!z}+\unicode[STIX]{x1D6FD}\unicode[STIX]{x1D64B}_{\!\bot }),\end{eqnarray}$$
where both
 $\unicode[STIX]{x1D6FC}$
and
 $\unicode[STIX]{x1D6FD}$
are
 $O(1/\ln \unicode[STIX]{x1D705})$
. In terms of components,
 $$\begin{eqnarray}{\mathcal{E}}_{zz}\sim \unicode[STIX]{x1D6FC}R^{-1},\quad {\mathcal{E}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D70C}}\sim {\mathcal{E}}_{\unicode[STIX]{x1D719}\unicode[STIX]{x1D719}}\sim \unicode[STIX]{x1D6FD}R^{-1}.\end{eqnarray}$$
The symbol ‘
 ${\sim}$
’ is used in the asymptotic analysis sense; in the present case it means that the difference between a left-hand and right-hand expression vanishes faster than
 $1/\ln \unicode[STIX]{x1D705}$
as
 $\unicode[STIX]{x1D705}\rightarrow 0$
.
Inserting the expressions (3.23) into (3.12a
), and replacing longitudinal arc length
 $\ell$
by axial coordinate
 $z$
, which is legitimate up to a correction of relative order
 $\unicode[STIX]{x1D705}^{2}$
, yields
 $$\begin{eqnarray}\boldsymbol{U}_{p}\sim \frac{\unicode[STIX]{x1D707}}{{\mathcal{D}}}\int \left(\unicode[STIX]{x1D705}\frac{\text{d}R^{\ast }}{\text{d}z}J_{0}(z)\boldsymbol{e}_{z}-\frac{1}{2}\boldsymbol{J}_{\bot }(z)\right)\frac{\text{d}z}{2}.\end{eqnarray}$$
These are the leading-order contributions to each component, in an expansion in
 $|\ln \unicode[STIX]{x1D705}|^{-1}$
. That the axial component is
 $O(\unicode[STIX]{x1D705})$
, while the transverse is
 $O(1)$
comes from (3.12a
), not from the asymptotic expression for the surface traction. A special case of (3.24), that of an axisymmetric flux distribution (
 $\boldsymbol{J}_{\bot }=0$
) has been derived previously (Yariv Reference Yariv2011; Schnitzer & Yariv Reference Schnitzer and Yariv2015). Note that, since only the
 $z$
-component depends on
 $\unicode[STIX]{x1D705}$
at fixed flux density, if
 $\boldsymbol{J}_{\bot }$
is non-zero, the velocity will be nearly transverse for small enough
 $\unicode[STIX]{x1D705}$
.
We now consider rotation about an axis in the transverse plane and containing the origin. In the slender-body limit, the force generated on a short segment of the body at
 $z$
is equivalent to that for a pure translation with velocity
 $\unicode[STIX]{x1D734}\times \boldsymbol{r}$
because the velocity is nearly uniform when
 $z$
varies of order
 $\unicode[STIX]{x1D705}$
. Such reasoning clearly does not work for rotation about the
 $z$
-axis, but we know from the discussion in § 3.1 that we need not consider such rotation. Thus,
 $$\begin{eqnarray}\unicode[STIX]{x1D642}\unicode[STIX]{x1D734}\sim \unicode[STIX]{x1D640}(\unicode[STIX]{x1D734}\times \boldsymbol{r})=(-\unicode[STIX]{x1D640}\times \boldsymbol{r})\unicode[STIX]{x1D734},\end{eqnarray}$$
which gives
 $$\begin{eqnarray}\unicode[STIX]{x1D642}\sim -\unicode[STIX]{x1D640}\times \boldsymbol{r}\sim \unicode[STIX]{x1D6FD}\frac{z}{R}(\boldsymbol{e}_{\unicode[STIX]{x1D70C}}\boldsymbol{e}_{\unicode[STIX]{x1D719}}-\boldsymbol{e}_{\unicode[STIX]{x1D719}}\boldsymbol{e}_{\unicode[STIX]{x1D70C}}).\end{eqnarray}$$
The integral of this last expression over the surface is zero, verifying that asymptotically, the centre of resistance is located at the coordinate origin. Insofar as the force on a length
 $\text{d}z$
of the body is independent of
 $R^{\ast }$
, and therefore the torque on said segment depends only on
 $z$
, this was actually fairly obvious. However, to find
 $\unicode[STIX]{x1D734}$
we do need the leading-order components
 $$\begin{eqnarray}{\mathcal{G}}_{\unicode[STIX]{x1D70C}\unicode[STIX]{x1D719}}=-{\mathcal{G}}_{\unicode[STIX]{x1D719}\unicode[STIX]{x1D70C}}\sim \unicode[STIX]{x1D6FD}z/R.\end{eqnarray}$$
Applying (3.12b ) now gives
 $$\begin{eqnarray}\unicode[STIX]{x1D734}_{p}\sim -\frac{3}{4}\frac{\unicode[STIX]{x1D707}}{{\mathcal{D}}}\int \boldsymbol{e}_{z}\times z\,\boldsymbol{J}_{\bot }(z)\,\text{d}z.\end{eqnarray}$$
4 Concluding remarks
The slender-body results (3.24) and (3.28) promise to be good only to within corrections of relative order
 $1/\ln \unicode[STIX]{x1D705}$
. Schnitzer & Yariv (Reference Schnitzer and Yariv2015) showed that for the particular slender-body family comprised of highly eccentric spheroids, the corrections to the axial component of
 $\boldsymbol{U}_{p}$
are actually algebraic. We now see that the correction is even of relative order
 $\unicode[STIX]{x1D705}^{2}$
: the only differences between the spheroid formulas and the slender-body formulas are the factor
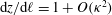 $\text{d}z/\text{d}\ell =1+O(\unicode[STIX]{x1D705}^{2})$
inside the integrals (3.17) and (3.20) and the prefactor
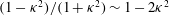 $(1-\unicode[STIX]{x1D705}^{2})/(1+\unicode[STIX]{x1D705}^{2})\sim 1-2\unicode[STIX]{x1D705}^{2}$
. An interesting aspect of the slender-body velocity (3.24) for the case that
 $\boldsymbol{J}_{\bot }\equiv 0$
is the factor of
 $\text{d}R^{\ast }/\text{d}z$
. On its face, this says that the flux on the sides of a cylinder is completely ineffective, and only the ends contribute to motion. This harsh verdict may be mitigated by deviation from the slender-body limit or, more likely, by significant thickness of the interfacial layer. More interestingly, it says that a shape which is pinched near the middle of its length, with flux of opposite signs on the two ends, but only on the parts where
 $R$
increases moving away from the centre (inert endcaps) will go backward with respect to expectations based on experience with fully convex motors. It may be that the phenomenon is not intrinsically linked to the slender-body limit. In that case, the most experimentally accessible geometry may be a pair of fused Janus spheres, with the active hemispheres facing each other.
Acknowledgement
This work was supported by the NSF under grant DMR-1420620 through the Penn State Center for Nanoscale Science.


