





1. Introduction
The importance of maritime transport in today’s globalised world is widely recognised, to the point of being referred to as the ‘backbone of global trade’ (UNCTAD, 2025). Any event that compromises its proper functioning can lead to human and economic consequences of a magnitude that is difficult to fully quantify (Khoi et al., Reference Khoi Tran, Haralambides, Notteboom and Cullinane2025). The types of maritime accidents are highly diverse and it is important to recognise that, as with all kinds of accidents, the underlying causes can vary widely (Ma et al., Reference Ma, Ma, Zhang and Du2025).
Analyses of ship collisions identify human supervision errors, ‘unsafe supervision’ (Guo et al., Reference Guo, Chen, Yuan, Zhang, Lv and Cai2025), such as failure to maintain a proper lookout and delayed decision-making, as major risk factors.
Any study on maritime collisions must be based on two fundamental pillars:
-
1. on the one hand, the regulatory framework, which conditions any intended solution: the International Regulations for Preventing Collisions at Sea (COLREGs), (IMO, 1972);
-
2. on the other hand, the human factor, i.e. the team responsible for implementing in real-life the possible solutions to be provided: the Officers in charge Of a Navigational Watch (OONWs) (IMO, 1973, 2014).
Concerning the regulatory framework, misinterpretation of the rules is one of the key factors contributing to maritime collisions (Du et al., Reference Du, Valdez Banda, Goerlandt, Huang and Kujala2020; Hatlas-Sowinska and Wielgosz, Reference Hatlas-Sowinska and Wielgosz2022).
As for the human element, poor or absent communication between OONWs significantly contribute to collision risk (Du et al., Reference Du, Valdez Banda, Goerlandt, Huang and Kujala2020; Hatlas-Sowinska and Wielgosz, Reference Hatlas-Sowinska and Wielgosz2022).
Mitigating these factors, by providing OONWs with enhanced tools for early detection and manoeuvring decisions in compliance with COLREGs, could substantially reduce the likelihood of collisions.
Argüelles et al. (Reference Argüelles, Maza and Martín2019, Reference Argüelles, Maza, Martín and Bartolomé2021) presented the specification and outlined the development of a safety-related system aimed at reducing the risk of ship collisions, with a focus on the aforementioned preventive measures. With the data received from a ship’s Automatic Identification System (AIS), this system:
-
1. calculates key values for each vessel within a predefined radius, as distance, bearing, relative course and speed, Closest Point of Approach (CPA), and Time to CPA (TCPA);
-
2. identifies the type of encounter and determines the applicable COLREGs when necessary;
-
3. determines the risk areas involving all surrounding vessels.
Another worrying situation that has been identified is the failure of the algorithms described in the literature to adequately adapt to COLREGs (Sánchez-González et al., Reference Sánchez-González, Rodrigues-Tomé, Cardoso-Mestre and García-Maza2025). This situation needs to be corrected, which is one of the objectives of this work.
Building on this foundational system, a software application (Carrizo et al., Reference Carrizo, Argüelles and Maza2025) has been implemented. It displays the received and calculated data, along with the risk areas, providing the OONW with an intuitive visualisation of the current risk situation and supporting the selection of the most appropriate manoeuvres to exit all risk scenarios according to COLREGs. The images illustrating the example scenarios in this paper have been generated with this software.
Based on the graphical representation of risk areas, additional information can be generated and displayed to further assist OONWs, including:
-
1. the percentage of risk-free zones and the remaining time window available for performing manoeuvres to ensure safe navigation during encounters with multiple ships in high seas;
-
2. quick selection of the most favourable manoeuvres.
This paper presents algorithms developed for the automatic identification of risk-free areas and the manoeuvres required to ensure safe navigation during encounters with multiple vessels in high seas. These algorithms are based on the sequence of considerations and decisions typically undertaken by the OONW to navigate safely towards the next waypoint in multi-ship encounter scenarios. The information generated by these algorithms could be integrated into an autonomous navigation system.
The rest of the paper is structured in the following sections.
-
1. The initial step in analysing the hazard level of an encounter involves the definition of a set of parameters to assess the risk. These parameters are outlined in section 2 and, based on them, a classification of unsafe encounters is established.
-
2. The third section introduces the velocity areas, polar graphs where coordinates correspond to own ship velocity vectors (radius = speed, angle = heading) and sectors that encompass values of speed and heading, which cause unsafe encounters with ships located within a predefined range. A brief review of terms and methods related to the same concept of risk areas is also included.
-
3. The fourth section describes the algorithms developed based on velocity polar graphs to calculate the percentage of risk-free zones and to estimate the time available before performing a manoeuvre towards a safe area in multi-ship encounters. This information is essential for the OONW to carry out situation assessment and decision-making without delay.
-
4. The fifth section describes the decision-making process for safe navigation between two waypoints, modelled as a discrete event system. Within this process, two stages can be highlighted: the estimation of the most appropriate manoeuvre, once a risk situation has been detected and the need to manoeuvre has been determined, and that of resuming the course to the next waypoint on the route.
-
5. Sections 6 and 7 describe the algorithms developed for the automatic determination of the most suitable manoeuvre, taking into account the COLREGs.
-
6. Section 8 is devoted to outline the algorithm for determining when and how to return to the planned route.
-
7. Finally, section 9 presents some conclusions of this research.
2. Definition of scenarios and risk situations
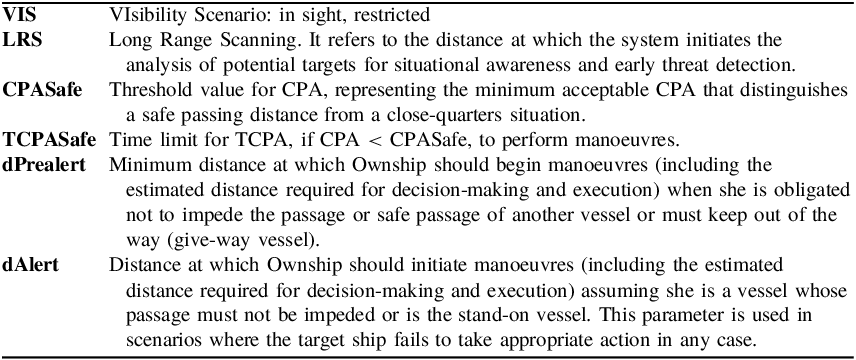
The first issue to be addressed is the definition of when a given encounter can be classified as hazardous (Xue et al., Reference Xue, Clelland, Lee and Han2011). To assess whether an encounter between the own ship (hereinafter referred to as Ownship) and another ship (target) poses a safety risk and to enable appropriate action, the parameters outlined in Table 1 have been defined (Argüelles et al., Reference Argüelles, Maza, Martín and Bartolomé2021).
Required parameters for risk assessment.

Table 1. Long description
A table titled Required parameters for risk assessment. The table has six rows and two columns. The columns are labeled with abbreviations and their descriptions. Row 1: VIS, VISibility Scenario: in sight, restricted. Row 2: LRS, Long Range Scanning. It refers to the distance at which the system initiates the analysis of potential targets for situational awareness and early threat detection. Row 3: CPASafe, Threshold value for CPA, representing the minimum acceptable CPA that distinguishes a safe passing distance from a close-quarters situation. Row 4: TCPASafe, Time limit for TCPA, if CPA < CPASafe, to perform manoeuvres. Row 5: dPrealert, Minimum distance at which Ownship should begin manoeuvres (including the estimated distance required for decision-making and execution) when she is obligated not to impede the passage or safe passage of another vessel or must keep out of the way (give-way vessel). Row 6: dAlert, Distance at which Ownship should initiate manoeuvres (including the estimated distance required for decision-making and execution) assuming she is a vessel whose passage must not be impeded or is the stand-on vessel. This parameter is used in scenarios where the target ship fails to take appropriate action in any case.
For each target located at a distance less than or equal to the LRS threshold, the encounter is subsequently analysed and classified as either safe or unsafe based on the CPA as follows.
-
1. Safe Encounter: CPA ≥ CPASafe. No risk is present.
-
2. Close-Quarters Situation: CPAcq = {CPA | CPAcoll < CPA < CPASafe}. Unsafe situation that would require some action to ensure passing at a safe distance and thereby avoid the risk of collision.
-
3. Collision: CPA ≤ CPAcoll. In this study, CPAcoll will be considered as the sum of the maximum lengths of both vessels. A collision is considered imminent or occurring.
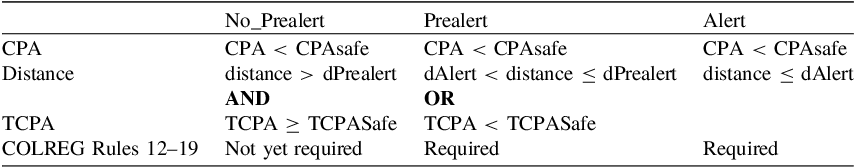
When an encounter is determined to be unsafe (CPA < CPASafe), it can be classified into one of three states, based on the spatial and temporal proximity of the target and the applicable COLREGs.
-
1. No_Prealert: (CPA < CPAsafe) AND (distance > dPrealert) AND (TCPA ≥ TCPASafe). This represents a risky situation, but there remains sufficient time and space for manoeuvring. At this stage, vessels are not yet required to take action under COLREG Rules 12–19.
-
2. Prealert: (CPA < CPASafe) AND [(dAlert < distance ≤ dPrealert) OR (TCPA < TCPASafe)]. In this state, manoeuvres must comply with COLREGs. The give-way vessel is required to take action in accordance with Rules 13–16. In conditions of restricted visibility, both vessels are required to act in accordance with Rule 19.
-
3. Alert: This state corresponds to a Prealert condition with the additional constraint (distance ≤ dAlert). Here, the stand-on vessel, as defined by COLREGs, is also required to take action, in compliance with Rule 17.
Table 2 summarises the characteristics of the risk states in an unsafe encounter. The parameter values shall be set based on the dynamic characteristics of Ownship, which determine both the settling time and the distance required to complete a predefined long-duration manoeuvre.
Summary of risk states in an unsafe encounter.

Table 2. Long description
A table comparing risk states in unsafe encounters. The table has four rows and four columns. The columns are labeled No_Prealert, Prealert, and Alert. The rows are labeled CPA, Distance, TCPA, and COLREG Rules 12-19. For No_Prealert, CPA is less than CPAsafe, distance is greater than dPrealert, TCPA is greater than or equal to TCPASafe, and COLREG Rules 12-19 are not yet required. For Prealert, CPA is less than CPAsafe, dAlert is less than distance is less than or equal to dPrealert, TCPA is less than TCPASafe, and COLREG Rules 12-19 are required. For Alert, CPA is less than CPAsafe, distance is less than or equal to dAlert, TCPA is less than TCPASafe, and COLREG Rules 12-19 are required.
It must be clearly stated that, in this paper, the phrase ‘not yet required to take action under COLREGs’ refers specifically to the rules that mandate a particular manoeuvre – whether in sight or in restricted visibility – namely, Rules 12–19 inclusive. As explicitly or implicitly stated in each of these rules, their applicability depends on the existence of a situation that ‘involves risk of collision’. The remaining rules, such as those concerning proper lookout, safe speed and others, are always applicable.
Ideally, each ship should be aware of the safety parameters of nearby ships – either through direct communication, as proposed by Argüelles et al. (Reference Argüelles, Maza, Martín and Bartolomé2021), or via automatic broadcast, for example, by including such parameters in the static AIS messages (Message No. 5 for Class A or No. 24 for Class B). This would enable both ships (Sh0, Sh1) involved in an encounter to detect Prealert and Alert states simultaneously, allowing for coordinated and timely manoeuvring decisions. For this purpose, the higher of the two values is selected for each parameter:
-
1. CPASafe = max(CPASafeShO, CPASafeSh1);
-
2. TCPASafe = max(TCPASafeShO, TCPASafeSh1);
-
3. dPrealert = max(dPrealertShO, dPrealertSh1);
-
4. dAlert = max(dAlertShO, dAlertSh1).
In this case, the OONWs would have accurate information about the situation of the other vessel, including her attitude.
3. Risk areas and polar charts
The range of Ownship velocity vectors (speed, heading) can be represented using a polar graph. This diagram includes the sectors corresponding to Ownship speed and heading (SO, HO) coordinates that produce unsafe encounters (CPA < CPASafe) with targets located at a distance ≤ LRS, assuming that they maintain their current speed and heading.
We will call these risk areas forbidden sectors. The name has been selected as a tribute to two authors whose contributions in the field of kinematics have been overlooked in contemporary literature, as will be detailed later.
At all other points outside these sectors on the polar graph, Ownship is not at risk of collision with any target, provided they maintain their current speed and heading. Figure 1 illustrates an example of a forbidden sector.
Example of a forbidden sector.

The static (instantaneous) angles A1 and A2, related to the limiting relative courses RC1 and RC2 and measured with respect to the target, are computed using the following expressions:
 $$A1 = {{Bearing}} - {{arcsin}}\left( {{{{{CPASafe}}} \over {{{distance}}}}} \right)={\rm{rC}}1+{180^\circ }$$
 $$A2 = {{Bearing}} + {{arcsin}}\left( {{{{{CPASafe}}} \over {{{distance}}}}} \right)={\rm{rC}}2+{180^\circ }$$
In the example, these values are: A1 = 55.5°; A2 = 82.5°; rC1 = 235.5°; rC2 = 262.5°.
The limit values of Ownship heading (HO1, HO2) corresponding to values A1 and A2 depend on the speed (SO). In the example, for SO = 15kn, the values for HO1 and HO2 are respectively 347° and 22.9°. For SO = 30kn, HO1 = 27.8° and HO2 = 57°.
In a similar vein, these forbidden sectors are often referred to as ‘Velocity Obstacle’ (VO) regions in the recent literature. This terminology, widely used in the field of robotics (Fiorini and Schiller, Reference Fiorini and Shiller1998), denotes the set of all vectorial velocities of a robot that would lead to a collision with another robot at some future time, assuming the latter maintains its current velocity. The following sentence is extracted from this paper: ‘In case of a collision, a trajectory correction is computed that avoids the forecast collisions. The trajectory correction may consist of several maneuvers in which the object’s velocity vector may change in direction and/or modulus.’
Although this reference is usually cited as the origin (Kuwata et al., Reference Kuwata, Wolf, Zarzhitsky and Huntsberger2014), the underlying principles of defining navigational risk areas have been explored in earlier works.
Notably, Carrero (Reference Carrero1941) introduced the ‘Forbidden arch of approach’, and defined it as
‘Geometric locus of all relative positions of vessel A corresponding to its minimum distance from vessel B.’
In this book, he described the calculation of manoeuvring courses to pass another vessel at a specific distance. Once the approach circle connecting both vessels is established, he conditioned the manoeuvring possibilities to the speed ratio between the two ships, a concept rarely addressed in recent studies.
In this way, if Ownship is faster than the target, the full range of manoeuvring options is available and the entire circumference of the approach circle may be used. It is enough to select a CPASafe to determine the corresponding arc of the approach circle.
However, if the target has a higher speed than Ownship, as shown in the example in Figure 2, those manoeuvring possibilities are reduced. All courses within the shaded sector will result in CPA < CPASafe, whereas those outside this sector ensure a safe CPA.
Example of forbidden arch of approach: original and redrawn images.

Figure 2. Long description
Panel A: A diagram showing the original image of the forbidden arch of approach. It features a series of lines and arcs labeled with points A, B, D, and P, indicating different positions and paths. The diagram includes various angles and intersections, with a focus on the relationships between these points. Panel B: A redrawn image of the forbidden arch of approach. It includes points A, B, and multiple points labeled A1 through A6, with lines connecting these points to form arcs and angles. The diagram also features colored sections and arrows indicating directions and relationships between the points.
García-Frías (Reference García-Frías1965), for his part, proposed the ‘Sector Rule’.
Figure 3 left and the following text are extracted from García Frías (Reference García-Frías1965):
We have vectors VAI and VAII defined by the points of intersection of these parallels with the arc of radius VA. It is then easy to see that these vectors are the limits between the forbidden sector – that containing vector VA – and the evading sector. Of these limiting vectors, VAI implies a course crossing astern of B and VAII a crossing ahead. If it is desired to manoeuvre on speed only, vector VAIII leads to the same miss distance as VAI – the forbidden sector being then the one comprised by vectors VAIII and VAIV. If the manoeuvre is performed by alterations of both course and speed, the forbidden sector depends on the selected speed, as, for example, by the vectors VAV and VAVI.
Example of sector rules: original and redrawn images.

Hence, the designation of forbidden sectors.
The straight lines delimiting forbidden sectors or VO regions have been obtained without considering ship inertia and, consequently, the nonlinear nature of ship motion, particularly during manoeuvres involving substantial changes in heading and speed. These boundaries would appear curved if ship dynamics and manoeuvrability models were taken into account (Kanazawa et al., Reference Kanazawa, Wang, Ichinose, Skulstad, Li and Zhang2023; Zhao et al., Reference Zhao, He, Huang, Mou, Zhang and Liu2022).
Dong et al. (Reference Dong, Zhen and Gu2024) provide an extensive review on the VO method and related research on the multi-ship collision avoidance problem. In their work, they propose a multi-ship collaborative collision avoidance decision model based on the VO approach, enabling ships to simultaneously adjust both their course and speed. This model requires a Vessel Traffic Service (VTS) responsible for determining the optimal avoidance decision and communicating it to all ships. Each ship is assumed to receive the instruction and respond to it immediately. This solution would be limited to areas close to the coast where effective traffic control is possible, both because of technical and legal requirements.
4. Percentage of free areas and time frame for manoeuvring
Based on the polar graph depicting the forbidden sectors for all targets within a distance less than LRS, valuable information can be extracted to assist OONWs in executing manoeuvres towards risk-free zones. This information, in real time, provides an overview of the evolution of the situation, based on the speed at which the area of the non-prohibited sectors is being reduced. This includes determining the available area and the time frame within which to execute the manoeuvre. The corresponding algorithms are outlined in this section.
The process of digitising the polar plot to quantify the proportion of risk-free areas involves constructing a three-dimensional Boolean matrix PB3M(NS, NH, NT), where
The final graph will result from the logical sum of the levels for all the targets:
 $$PSM\left( {i,j} \right)=\sum\limits_{k = 1}^{NT} P B3M\left( {i,j,k} \right)$$
The percentage of free area at each instant is derived from the PSM FALSE values:
 $${\rm{Percentage}} = {\rm{FALSECells}}^*100/{\rm{TotalCells}}$$
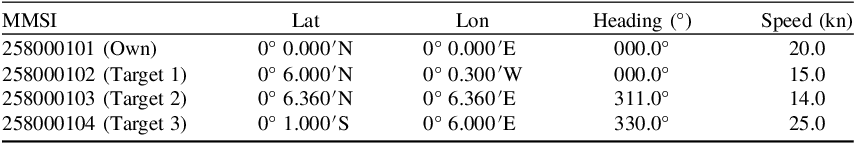
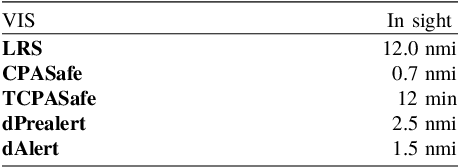
As an example, assume the scenario and safe parameters shown in Tables 3 and 4.
Scenario1 with three targets.

Table 3. Long description
The table has four rows and five columns. The columns are labeled MMSI, Lat, Lon, Heading (degrees), and Speed (kn). The rows are labeled as follows: Row 1: MMSI, 258000101 (Own); Lat, 0 degrees 0.000’N; Lon, 0 degrees 0.000’E; Heading, 000.0 degrees; Speed, 20.0 kn. Row 2: MMSI, 258000102 (Target 1); Lat, 0 degrees 6.000’N; Lon, 0 degrees 0.300’W; Heading, 000.0 degrees; Speed, 15.0 kn. Row 3: MMSI, 258000103 (Target 2); Lat, 0 degrees 6.360’N; Lon, 0 degrees 6.360’E; Heading, 311.0 degrees; Speed, 14.0 kn. Row 4: MMSI, 258000104 (Target 3); Lat, 0 degrees 1.000’S; Lon, 0 degrees 6.000’E; Heading, 330.0 degrees; Speed, 25.0 kn.
Safe parameters.

Table 4. Long description
Table with two columns labeled VIS, LRS, CPASafe, TCPASafe, dPrealert, and dAlert in the first column and In sight, 12.0 nmi, 0.7 nmi, 12 min, 2.5 nmi, and 1.5 nmi in the second column.
Figure 4 shows the current data and situation, from the mentioned software application (Carrizo et al., Reference Carrizo, Argüelles and Maza2025) with data obtained from a simulated AIS (Kågstrøm, Reference Kågstrøm2025). The four vessels are under way using engine (navigation Status code = 0). None of the targets has triggered a pre-alert condition yet; therefore, compliance with COLREG manoeuvring rules is not required at this stage, and any manoeuvre may be selected. If a pre-alert had been issued for any of the targets, the situation and manoeuvre shown at the top of the figure would be highlighted, indicating that compliance is mandatory.
Forbidden sectors, data and situation.

In the example scenario, executing ‘simple’ manoeuvres such as:
-
1. a 15° heading turn to port;
-
2. a 47° turn to starboard;
-
3. a speed reduction to 15 knots,
or ‘combined’ actions such as:
-
1. reducing speed to 17 knots while turning 5° to starboard; or
-
2. increasing speed to 25 knots while turning 30° to starboard,
can effectively move Ownship out of the forbidden sectors. The time required to achieve a safe position depends on the manoeuvrability of Ownship and the relative velocities of targets.
While manoeuvring, the forbidden sectors will continue to expand; however, their shape and extent will evolve in response to the manoeuvre.
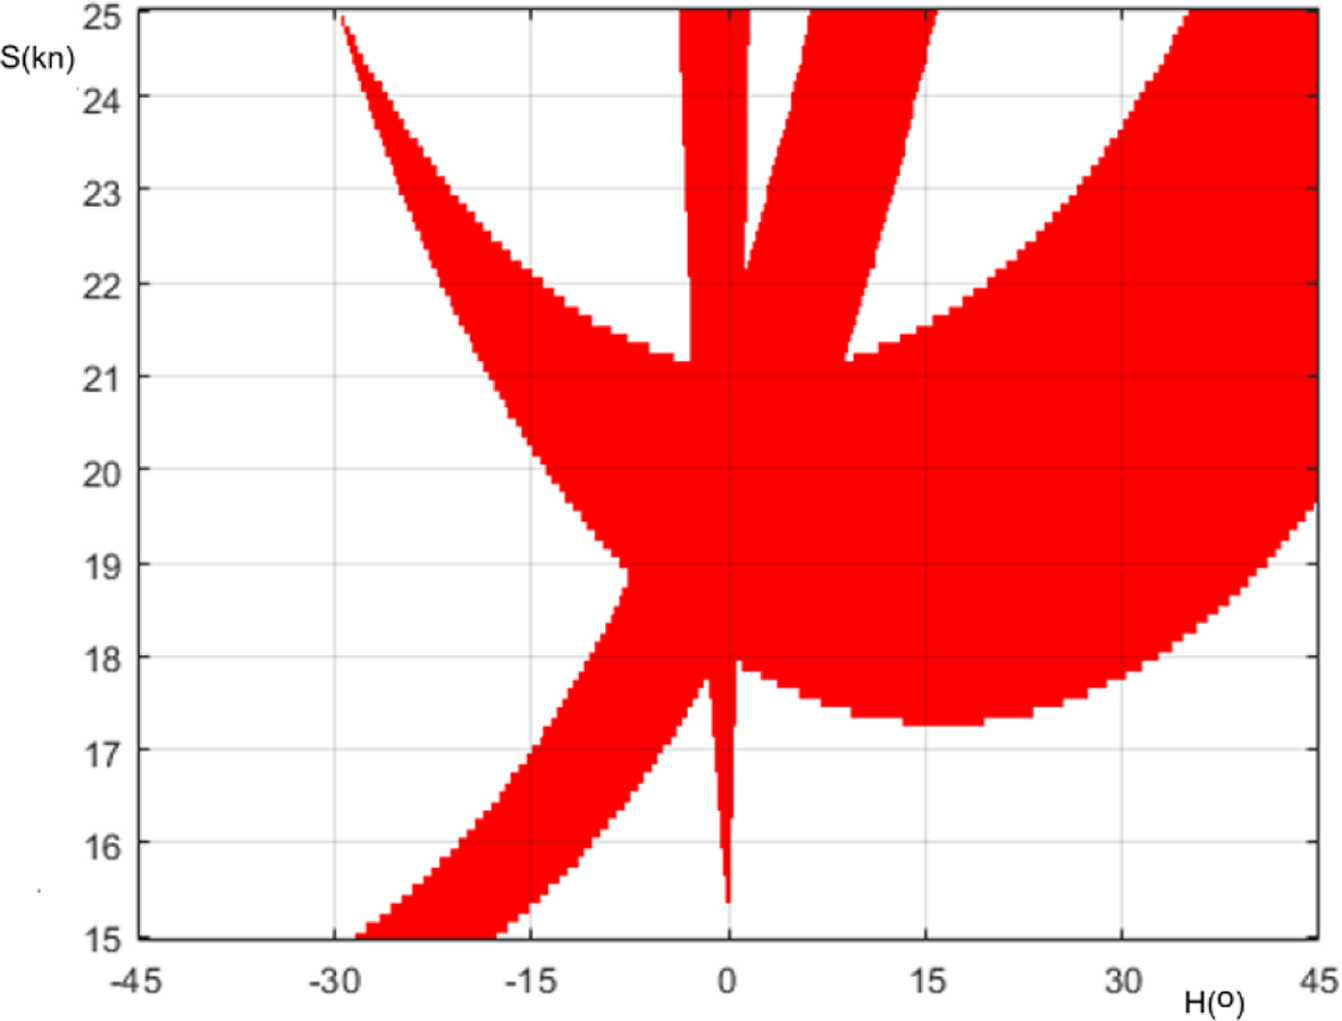
Figure 5 shows the graph of the forbidden sector matrix PSM for the specified Ownship speed and heading ranges.
Boolean matrix graph of forbidden sectors for S = 15:0.5:25, H = –45:0.5:45. Free area = 60%.

Based on the current values of the speed and heading vectors (S, H) of Ownship and targets, it is possible to estimate the evolution of the forbidden sectors at future time instants – assuming that these vectors remain constant. This also allows for the early estimation of free areas in the selected ranges, providing insight into the remaining time available for decision-making and manoeuvring.
Taking into account the manoeuvrability characteristics of Ownship, the simplest method of action involves selecting a minimum threshold for the percentage of free area required for manoeuvring (PMin) and calculating positions, CPAs, TCPAs and free areas by iterating over a time variable until the area drops below this threshold:
For the above example, after 13 minutes without manoeuvring, the free area at the defined speed and heading limits would be less than 36%, as shown in Figure 6.
Forbidden sectors for S = 15:0.5:25, H = −45:0.5:45 at time = T0 + 13min. Free area = 35.4%.

Figure 6. Long description
Panel A: A polar plot shows forbidden sectors for ship collision avoidance. The plot is divided into four quadrants labeled N, E, S, and W. Red and purple sectors indicate forbidden areas, while blue areas represent permissible regions. Panel B: A Cartesian plot displays the free area percentage as a function of heading angle (H) ranging from -45 to 45 degrees. The vertical axis represents the free area percentage (S) ranging from 15 to 25 percent. The red area indicates the forbidden regions, and the white area indicates the free regions.
5. Safe navigation model
If the current (SO, HO) values for Ownship are inside a forbidden sector, it is possible to estimate which manoeuvre is most appropriate. It is necessary to analyse how the feasible manoeuvres to leave the forbidden sector should be, depending on the three mentioned states (No_Prealert, Prealert, Alert) with respect to the corresponding target.
-
1. (CPA < CPASafe) AND No_Prealert: if the target is not manoeuvring, Ownship could manoeuvre in advance to leave the forbidden sector without complying with COLREG rules of manoeuvre (Rules 12–19).
-
2. (CPA < CPASafe) AND Prealert: the situation and manoeuvres are analysed according to COLREG (Arguelles et al., Reference Argüelles, Maza, Martín and Bartolomé2021):
-
i. if, according to Rules 13, 14, 15, 18, it is determined that Ownship is a Give-Way ship, or the encounter is in restricted visibility (Rule 19), Ownship must manoeuvre out of the forbidden sector. If the target is manoeuvring, an assessment shall be made as to whether it is possible to wait for the target to complete the manoeuvre before taking action, obtaining as much information as possible about the manoeuvre the target is making, by all means available: RADAR, AIS, etc;
-
ii. if it is determined to be Stand-On, Ownship shall only manoeuvre if the Alert state is entered.
-
Once the manoeuvre is completed, with Ownship in a safe position, it is necessary to return to the predefined path, setting a new course when the heading to the next waypoint is also outside the hazardous areas on the chart.
The decision-making process for safe navigation between two waypoints can be considered as a Discrete Event System (DES), i.e. an event-driven system of discrete states (Hansen et al., Reference Hansen, Papageorgiou, Blanke, Galeazzi, Lützen, Mogensen, Bennedsen and Hansen2020; Silva, Reference Silva2018). This DES can be modelled as a Finite State Machine (FSM), an oriented graph that consists of discrete states (or stages) represented by boxes and transitions between them represented by arrowed lines. The system occupies a single active state at any given time, with all other states remaining inactive. When the condition associated with a transition from the active state is true, that transition will be triggered, activating the new state and deactivating the previous one.
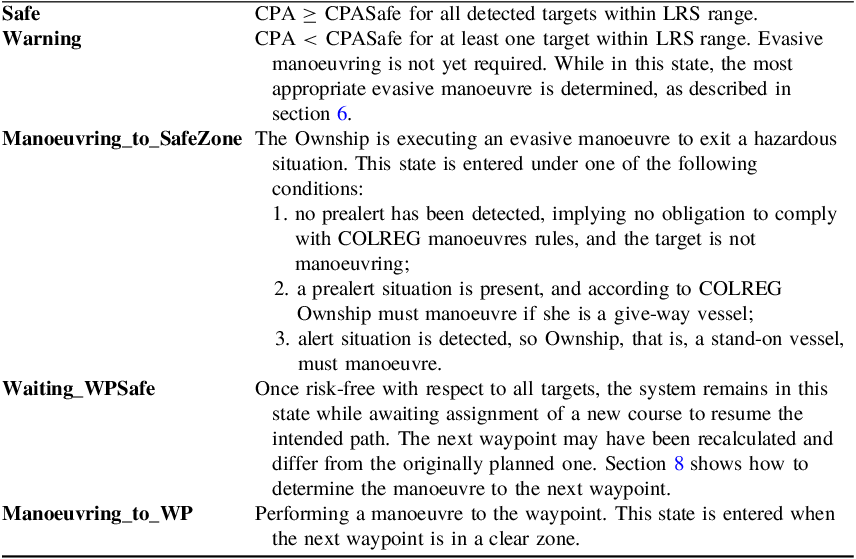
The sequence of stages originated during navigation when a risk situation (CPA < CPASafe) is detected at a distance ≤ LRS is summarised in Figure 7.
Stages in navigation.

Ownship will be in one of five stages, summarised in Table 5.
Description of stages in navigation.

Table 5. Long description
Panel A: Safe. CPA is greater than or equal to CPASafe for all detected targets within LRS range. Panel B: Warning. CPA is less than CPASafe for at least one target within LRS range. Evasive manoeuvring is not yet required. Panel C: Manoeuvring_to_SafeZone. The Ownship is executing an evasive manoeuvre to exit a hazardous situation. Panel D: Waiting_WPSafe. Once risk-free with respect to all targets, the system remains in this state while awaiting assignment of a new course to resume the intended path. Panel E: Manoeuvring_to_WP. Performing a manoeuvre to the waypoint.
6. Automatic selection of manoeuvres
The automatic selection of the optimal manoeuvre to move out of the forbidden sectors and get into a safe position with all targets after detecting a risk situation (step Manoeuvring_to_safeZone), is performed by digitising the polar plot of each target at a distance ≤ LRS, then combining all the graphs and finding the cell with the minimum value.
Instead of a Boolean matrix, as done in Section 4, a real matrix is created, with a numerical value in each cell that depends on several factors:
-
1. CPA and TCPA for Ownship cell coordinate values (S,H): CPA_P, TCPA_P;
-
2. difference in headings: DH = ABS(H-HO). IF DH > 180, DH = DH-180;
-
3. difference in speeds: DS = ABS(S-SO).
The weight assigned to each of these factors will be parametrised based on Ownship dynamics.
The digitising of the polar graph with respect to all targets within a distance less than LRS to determine the most favourable manoeuvre consists of creating a 3D real matrix PR3M(NS, NH, NT), where
The final 2D polar matrix (manoeuvre matrix) PRSM will result from the combination of the levels for all targets, giving each cell the highest value:
 $$PRSM\left( {i,j} \right) = MAX_{k = 1}^{NT}PR3M\left( {i,j,k} \right)$$
The manoeuvre to be carried out (SM, HM) corresponds to the values (S,H) of the cell in matrix PRSM with a local or absolute minimum value. Among the local minima within the considered velocity area, the cell with the lowest value will be selected, provided that:
-
1. the path from the current position to the minimum does not exceed a given maximum slope;
-
2. the deviation to the next waypoint resulting from the heading change is minimal.
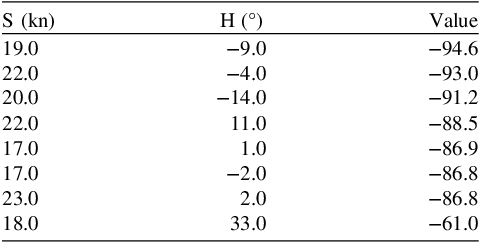
Continuing with the example in Figure 4, for speeds ranging from 5 to 30 knots and headings between −90° and 90°, and using representative trial values for the parameters to quantify the influence of CPA, TCPA, DS and DH, resulting local minima are presented in Table 6.
Local minima in the polar matrix.

Table 6. Long description
A table with three columns and eight rows. The columns are labeled S (kn), H (°), and Value. The rows present data for different speeds (S) in knots, headings (H) in degrees, and corresponding values. Row 1: S, 19.0; H, -9.0; Value, -94.6. Row 2: S, 22.0; H, -4.0; Value, -93.0. Row 3: S, 20.0; H, -14.0; Value, -91.2. Row 4: S, 22.0; H, 11.0; Value, -88.5. Row 5: S, 17.0; H, 1.0; Value, -86.9. Row 6: S, 17.0; H, -2.0; Value, -86.8. Row 7: S, 23.0; H, 2.0; Value, -86.8. Row 8: S, 18.0; H, 33.0; Value, -61.0.
Figure 8 shows a representation of the manoeuvre matrix.
Manoeuvring areas, S = 5:1:30, H = −90:1:90. Minimum: H = −9°, S = 19kn. Maximum: H = 60°, S = 30kn.

Figure 8. Long description
Panel A: A polar plot shows maneuvering areas with red sectors indicating forbidden regions. Panel B: A map displays the positions of four vessels labeled with unique identifiers. Panel C: A 3D surface plot illustrates the relationship between speed (S) in knots and heading (H) in degrees, with varying heights representing different maneuvering areas. The plot ranges from -90 to 90 degrees in heading and 5 to 30 knots in speed.
7. Guidelines for the calculation of manoeuvres according to COLREGs
The manoeuvre to exit forbidden sectors must comply with COLREGs for all targets with which Ownship is in a pre-alert state (as defined in Section 2). This section analyses all potential encounters between Ownship and a target, to define COLREG-compliant manoeuvring instructions and assign weights to the points on the polar matrix corresponding to that target. It should be noted that not only Rules 13, 14 and 15 related to overtaking, head-on and crossing situations are taken into account, but also Rule 18, on responsibilities between vessels related to their navigation status, which modifies priorities in the event of crossing with the target on the port side, and Rule 19 for manoeuvres with restricted visibility.
Zones that violate COLREGs will be penalised with positive weights, increasing with the magnitude of the heading and speed changes (DH and DS). Conversely, zones that comply with COLREGs will be rewarded with negative weights, with greater rewards assigned to smaller manoeuvres, but large enough, according to COLREG Rule 8, to be readily apparent to another vessel observing visually or by radar. Also, prioritising heading changes over speed changes.
-
a) Head-On
if Prealert then% Alter course to starboardAssign positive weights to the points on the polar plot located to port, beyond the port-side limit of the forbidden sector.Assign negative weights to the points on the polar plot located to starboard, beyond the starboard-side limit of the forbidden sector.end if -
b) Crossing starboard side
if Prealert then% Avoid crossing aheadAssign positive weights to the points with speeds and headings constrained by the port-side limit of the forbidden sector and the heading of the target.Assign negative weights to all remaining points.end if -
c) Crossing portside
if Prealert thenif Alert then% Ownship is compelled to manoeuvreAssign positive weights to the points on the polar plot located to port.Assign negative weights to the points on the polar plot located to starboard, beyond the starboard-side limit of the forbidden sector.elseif STATUS < Status Target then % Navigation Status% Ownship is the give-way vessel. Avoid crossing ahead of the other vessel’s bowAssign positive weights to points with speeds and headings constrained by the starboard boundary of the risk zone and the heading of the target.Assign negative weights to all remaining points.end ifend if -
d) Overtaking
if Prealert then% Alter course; if the required change is excessive, apply a speed reductionAssign negative weights to points located outside the boundaries of the forbidden sector.end if -
e) Being Overtaken
If Ownship is being overtaken and enters an Alert situation, she must also manoeuvre.
if Alert then% Alter course; if the required change is excessive, increase speedif Target on the starboard side then% Alter course to portAssign more negative weights to the points near the port boundaries of the forbidden sector.else% Alter course to starboardAssign more negative weights to the points near the starboard boundaries of the forbidden sector.end ifend if -
f) Procedure for an encounter with restricted visibility (COLREG #19)
In the case of restricted visibility and a Prealert situation, Rule 19 of the COLREGs applies. One of the key differences is that there is no Stand-On vessel; both vessels must manoeuvre.
Four situations must be considered: Overtaking, Being Overtaken (mentioned in Rule 19 (d) (i)), Forward of the beam, and Abeam or abaft the beam.
The proposed procedure is summarised in the following pseudocode:
The images in Figure 9 summarise the manoeuvring areas for Head-On, Crossing stb, Crossing ps (alert or Ownship status < Target status) and Overtaking situations, with trial weights that would need to be tailored based on the dynamic characteristics of the ship. The manoeuvres in case of restricted visibility are not shown in the figure, so as not to lengthen the illustration excessively.
Risk and manoeuvring areas COLREG compliant.

In an example similar to that of Figure 4, if Target3 (MMSI 258000104) were closer to Ownship and already in a Prealert situation, as shown in Figure 10, Ownship must manoeuvre, avoiding crossing ahead of Target3.
Forbidden sectors. Target3 in prealert (TCPA < TCPASafe).

Figure 10. Long description
Panel A: A polar diagram with a circular plot centered on the user’s vessel. The plot shows sectors marked in red indicating forbidden areas. The compass directions North, East, South, and West are labeled around the circle. Panel B: A detailed information panel on the right side displaying data for a target vessel with MMSI 258000104. The panel includes distance, bearing, relative speed, and course information.
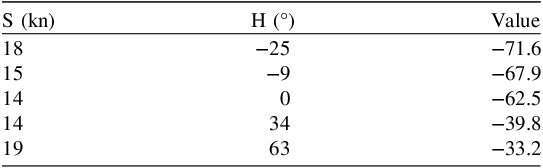
The manoeuvre matrix chart shows that the cells corresponding to headings and speeds that would result in Ownship crossing ahead of Target3 have positive values. Table 7 shows five local minima in the manoeuvre matrix.
Local minima in the polar matrix. Target3 in prealert.

Table 7. Long description
A table with three columns and five rows. The columns are labeled S (kn), H (°), and Value. The rows present the following data: Row 1: S, 18; H, negative 25; Value, negative 71.6. Row 2: S, 15; H, negative 9; Value, negative 67.9. Row 3: S, 14; H, 0; Value, negative 62.5. Row 4: S, 14; H, 34; Value, negative 39.8. Row 5: S, 19; H, 63; Value, negative 33.2.
Figure 11 shows two perspectives of this chart. With the selected trial weights, the most favourable manoeuvre (i.e. the most negative value) corresponds to a 25° turn to port and a speed of 18 knots. The cell associated with a heading of 58° and speed of 30kn has the maximum value, as it corresponds to a collision (CPA = 0) in 4 minutes, assuming Target3 maintains her current course and speed.
Manoeuvring areas, S = 5:1:30, H = −90:1:90. Minimum: H = −25°, S = 18kn.

8. Return to the planned route
Once the manoeuvre has been completed and Ownship is in a risk-free zone, she must return to the planned navigation route (stage Waiting_WPSafe in Figure 6). One possible approach is as follows: wait until the heading towards the next waypoint (HWP1) with the current Ownship speed (SO) lying outside the forbidden sectors indicated on the polar plot, or until the heading exceeds a predefined maximum limit (HWPMax). In such a case, the points along the line connecting the next waypoint and the subsequent one (WP1, WP2) are evaluated. The current heading is maintained until a point on this line lies outside the forbidden sectors. This point is then designated as the new heading.
Figure 12 illustrates a crossing scenario with the target on the Ownship starboard side, in Prealert state (TCPA < TCPASafe). The yellow point represents the current heading towards the waypoint at the current speed. The automated manoeuvre calculation suggests a 15° turn to starboard, as shown in Figure 13. Once Ownship reaches a risk-free sector (Figure 14), the heading towards the waypoint remains within the forbidden sector. Waiting for the waypoint heading to fall within a risk-free zone while maintaining the current course is shown in Figure 15. At this point, the ships are already moving away from each other. The heading to be set is 20° to port (HO = 355°).
Example of Crossing starboard.

Figure 12. Long description
Panel A: A polar diagram indicating directions North, South, East, and West. A yellow dot represents the current heading towards the waypoint at the current speed. Panel B: A map with a grid overlay and two triangular markers, one green and one yellow, representing ownship and target. A box with text displays information such as MMSI, Latitude, Longitude, Heading, Speed, Rate of turn, Distance, Bearing, Rel. Speed, CPA, and TCPA.
Manoeuvring areas, S = 10:1:30, H = −45:1:45. Minimum: H = 15°, S = 20kn.

Ownship in free area.

Figure 14. Long description
Panel A: A radar-like display with a circular grid. The grid is marked with cardinal directions: North (N), East (E), South (S), and West (W). Panel B: A map with coordinates and navigational data. Two vessels, ownship and target, are marked with their respective MMSI numbers. The target is shown with a heading of 230 degrees, a speed of 15 knots, and a rate of turn of 0 degrees per minute.
Waypoint in free area.

9. Conclusions
This study presents the algorithms designed to automatically identify forbidden and risk-free sectors and the manoeuvres necessary for safe navigation in multi-ship environments on the high seas. These algorithms rely on calculated data for each target (distance, bearing, relative course and speed, CPA, and TCPA), in combination with predefined safety parameters (VIS, LRS, CPASafe, TCPASafe, dPrealert and dAlert) and the pertinent COLREGs to be applied.
A Boolean polar matrix and a real-valued polar matrix were developed to determine the percentage of risk-free sectors and identify optimal manoeuvres, respectively. In both matrices, rows represent the range of speeds and columns represent the range of headings Ownship could adopt for manoeuvring.
In the Boolean matrix, each cell is assigned a value of true or false, indicating whether Ownship, at the corresponding speed and heading, is in a forbidden sector with respect to any target. In the real-valued matrix, each cell contains a numeric score: the lower the value, the more favourable the manoeuvre for reaching a risk-free zone. A positive value signifies that the manoeuvre would lead Ownship into a forbidden sector or into a situation that violates COLREGs. The value in each cell is determined based on the calculated CPA and TCPA relative to predefined safety thresholds (CPASafe and TCPASafe) for the manoeuvre defined by that cell’s polar coordinates. It also accounts for the magnitude of the heading or speed change required to execute the manoeuvre.
The selection of a manoeuvre, among the identified local minima, is influenced by two factors: the deviation it entails from the planned route, and the maximum elevation to be overcome in the topology of the matrix when transitioning from the current cell (SO, HO) to the one corresponding to the manoeuvre under consideration.
Tests conducted using simulated ships and predefined test parameters demonstrate the applicability and effectiveness of the proposed algorithms.
For the testing of the algorithms, a previously developed tool (Carrizo et al., Reference Carrizo, Argüelles and Maza2025) was also used. This tool allows for the visualisation of received and calculated data, as well as risk charts, and assists the OONW in the early identification and selection of suitable manoeuvres. The new algorithms are expected to provide enhanced decision-making support and, more importantly, show strong potential for integration into autonomous navigation systems.
Safety parameters determine the navigation state (safe, pre-alert or alert), which in turn indicates whether Ownship must execute a manoeuvre and how it should be carried out, in accordance with the COLREGs. Additionally, together with the magnitude of potential manoeuvres – expressed as changes in heading and/or speed – they influence the selection of the optimal manoeuvre. The quantification of these factors requires knowledge of the dynamic characteristics of the vessel to which they are to be applied.
Competing interests
The authors declare none.









 Open access

