1. Introduction
The concurrent programs we consider are made of finitely many sequential processes running in parallel. The idea that such programs could be interpreted geometrically was already present (yet not explicitly) in the work of Dijkstra (Reference Dijkstra1968); which was quickly followed by publications containing pictures of models that are subsets of
 ${\mathbb{R}}^n$
(Coffman et al. (Reference Coffman, Elphick and Shoshani1971); Kung et al. (Reference Kung, Papadimitriou and Yannakakis1979); Lipski and Papadimitriou (Reference Lipski and Papadimitriou1981)). The «geometry of concurrency» was formalized a bit later for programs
 $P$
whose processes neither have branchings or loops: their representations are subsets of
 ${\mathbb{R}}^n$
called progress graphs with
 $n$
being the number of processes of
 $P$
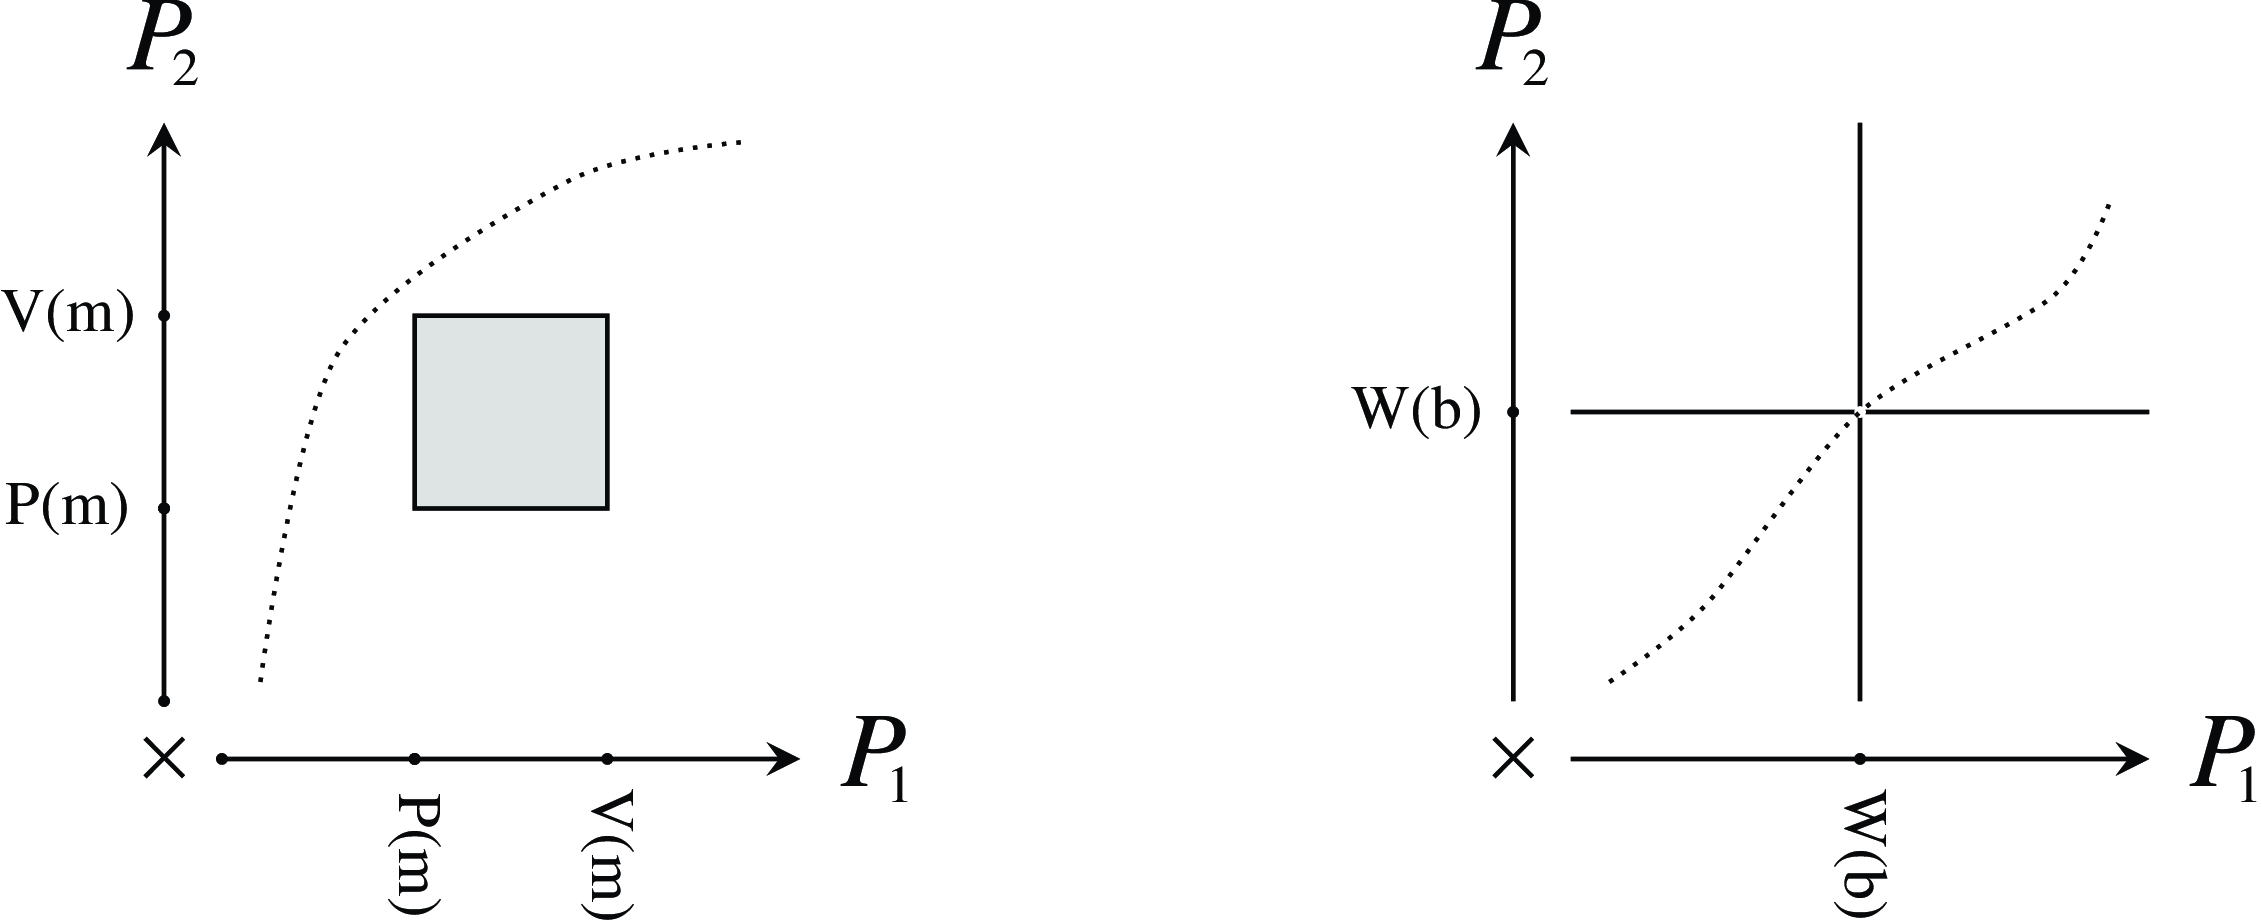
(Carson and Reynolds Reference Carson and Reynolds1987, §4). We recall two prototypical examples, both made of two processes
 ${{P}}_{{{1}}}$
and
 ${{P}}_{{{2}}}$
. In the first one, both try to take (P(m)) and release (V(m)) the mutex
 $m$
concurrently (whereas mutexes cannot be held by more than one process at the time). In the second one, both wait for each other (W(b)) behind the synchronization barrier
 $b$
. The corresponding progress graphs are
 ${\mathbb{R}}^2\setminus [{{1}},{{2}}]^2$
(up to subtleties at the boundary of the square) and
 ${\mathbb{R}}^2\setminus (\{x=1;\; y\not =1\}\cup \{x\not =1;\; y=1\})$
, that is,
 $\{(x,y)\in {\mathbb{R}}^2\mid x=1\Leftrightarrow y=1\}$
, they are displayed on Figure 1. The motivation for progress graphs is the relation between their directed paths (namely the componentwise order-preserving ones) and the execution traces of the programs they represent. For example, the dotted paths on Figure 1 induce the following execution traces:
Progress graphs.


Conversely, any execution trace is induced by a directed path on the progress graph. Following this principle, the progress graph by-product we are interested in is its collection of directed paths.
The «geometry of concurrency» described in (Carson and Reynolds (Reference Carson and Reynolds1987)) only applies to programs without branchings or loops. At the price of some extra mathematical machinery, this limitation can be overcome (Haucourt (Reference Haucourt2018)). The key feature of a progress graph of dimension
 $n$
is that its set of directed paths derives from the order and the metric inherited from
 ${\mathbb{R}}^n$
. Let
 $P$
be a program made of the processes
 ${{P}}_{{1},\ldots ,{{P}}_{n}}$
:
-
i) In accordance with the standard representation of sequential programs used in compilers (Aho et al. Reference Aho, Lam, Sethi and Ullman2007, §9.2), each
 ${{P}}_{{{i}}}$
is given as an automaton, which we associate with its underlying directed graph
${{G}}_{{{i}}}$
.
-
ii) Each directed graph
${{G}}_{{{i}}}$
induces a locally ordered metric graph
$|{{{G}}_{{{i}}}}|$
(Haucourt Reference Haucourt2018, §6.1). An execution trace of
${{P}}_{{{i}}}$
is seen as a directed path on
$|{{{G}}_{{{i}}}}|$
, so the set of directed paths on
$|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
is an overapproximation of the set of execution traces of
$P$
.


The process
 ${{P}}_{{{i}}}$
is said to be conservative when for any directed path
 $\gamma$
on
 $|{{{G}}_{{{i}}}}|$
the amount of resources held by
 ${{P}}_{{{i}}}$
after the execution of
 $\gamma$
only depends on the point where
 $\gamma$
stops; this property is decided by a breadth-first traversal of
 ${{G}}_{{{i}}}$
(Haucourt Reference Haucourt2018, §4.1, p. 1734–1735).
-
iii) If all the processes of
$P$
are conservative, we define its geometric model as the complement in
$|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
of the forbidden region of
$P$
(Carson and Reynolds Reference Carson and Reynolds1987, §4), (Haucourt Reference Haucourt2018, Def. 4.2).


Every directed path on a geometric model induces a sequence of multi-instructions that respect the constraints imposed by the synchronization mechanisms (mutexes, semaphores, and barriers) (Haucourt Reference Haucourt2018, Thm. 4.1). Moreover, directed paths that are metrically close to each other represent sequences of multi-instructions having the same effect on the state of the abstract machine (Haucourt Reference Haucourt2018, Thm. 6.1). Like progress graphs, geometric models are helpful abstractions of their directed paths. In this perspective, we aim at proving that the local order and the metric of the model of
 $P$
are by-products of a possibly non-Hausdorff parallelized manifold canonically defined from
 $P$
(it is Hausdorff if, and only if, the program under consideration has no branchings).
1.1 Motivation
For now, let us suppose that the geometric model
 $X$
is a subset of
 ${\mathbb{R}}^n$
(we may as well suppose that
 $X$
is one of the prototypical models in Figure 1). We give some facts about
 $X$
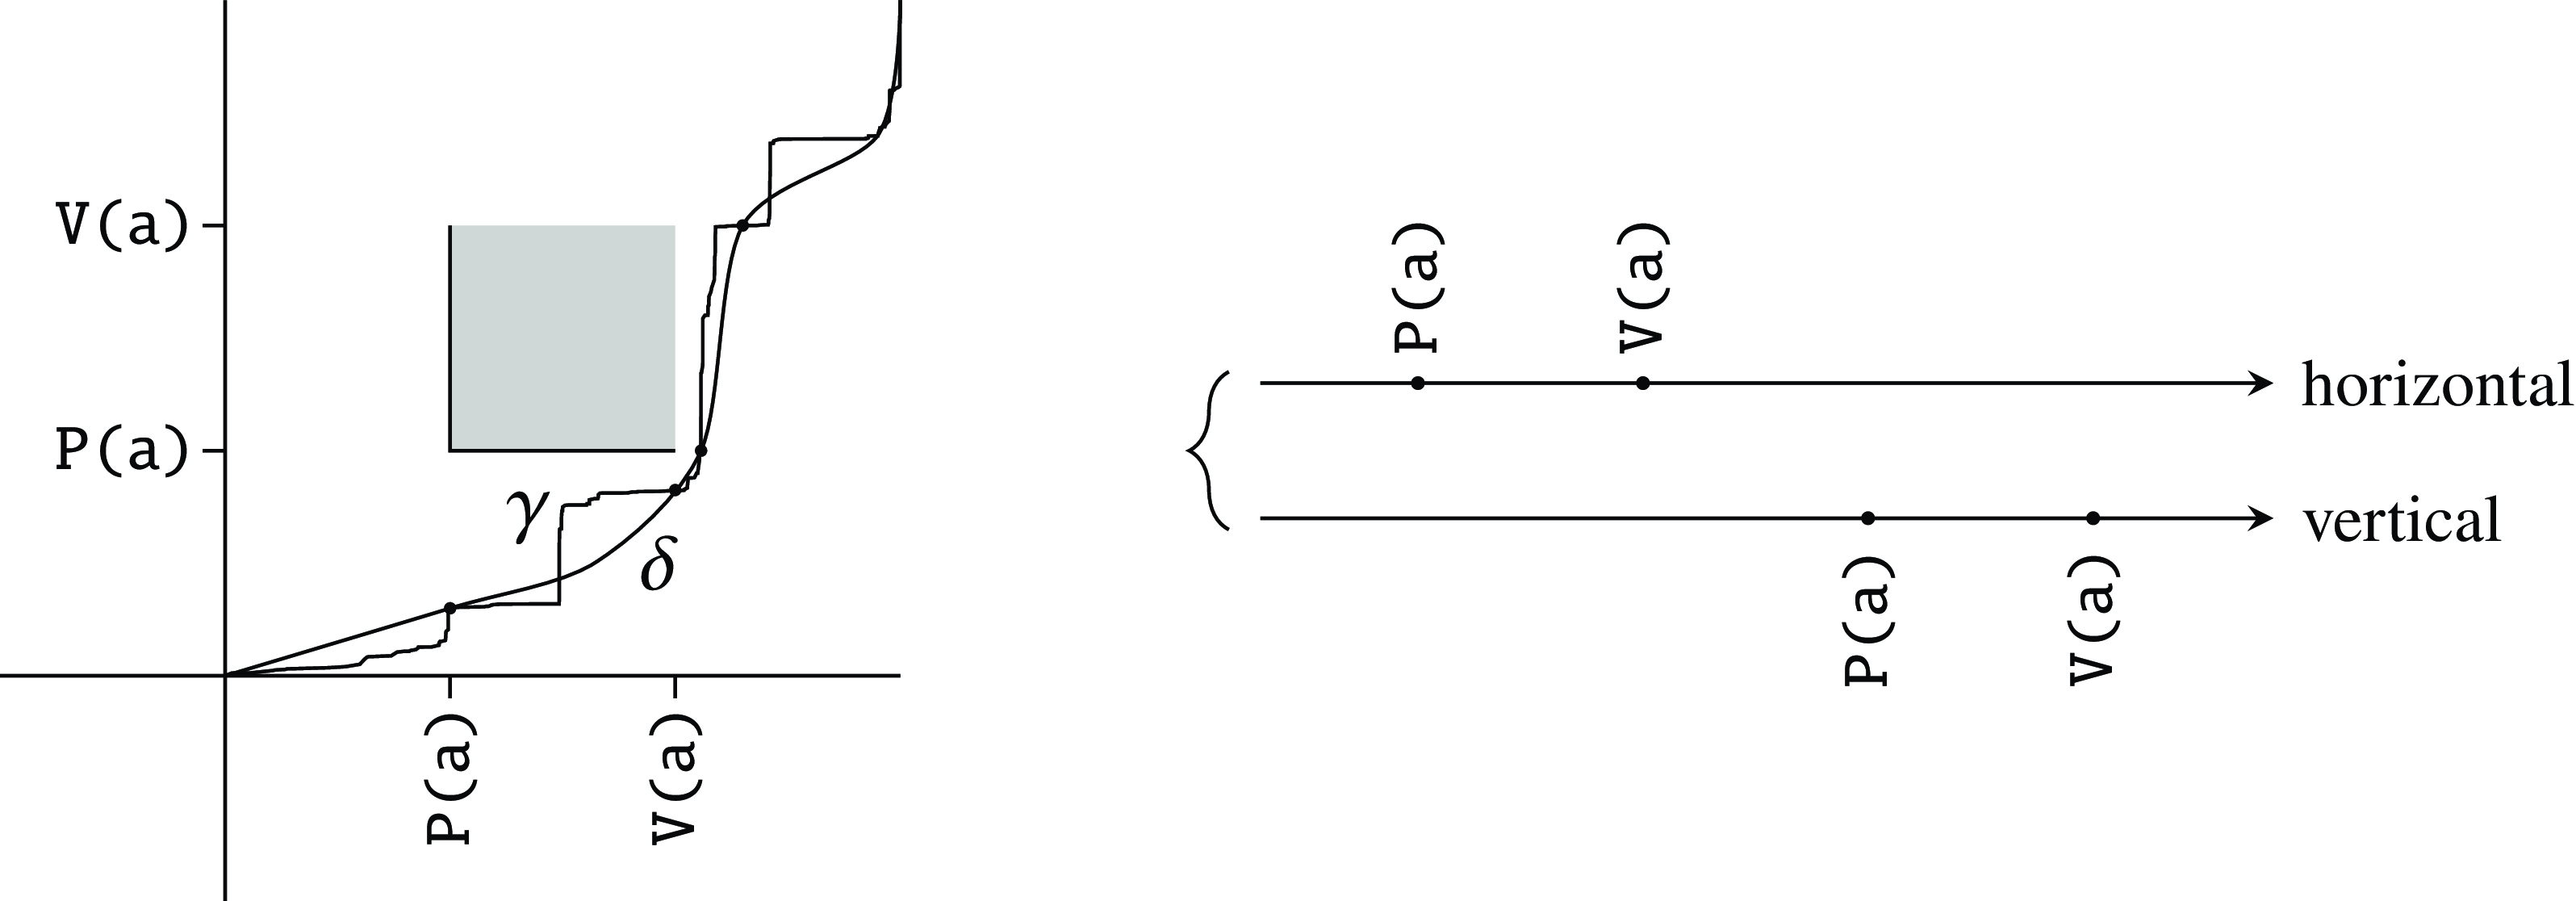
that will be proven later in the general setting of geometric models:
-
i) For any directed path
$\gamma$
on
$X$
, there is a directed smooth path
$\delta$
on
$X$
that is arbitrarily close to
$\gamma$
, and whose length is at most that of
$\gamma$
, see Figure 2. -
ii) If
$\delta$
is close enough to
$\gamma$
, then the sequence of multi-instructions they induce have the same effect on the state of the system. -
iii) The product metric on
${\mathbb{R}}^n$
can be chosen so that the lengths of
$\gamma$
and
$\delta$
correspond to execution times, so a (directed) path of lesser length represents a faster execution trace. -
iv) A smooth path on
$X$
is directed (i.e. order-preserving in all coordinates) if, and only if, all its tangent vectors belong to
$\mathbb{R}_{{+}}^n$
.


These properties suggest that the differential structure we expect is the standard manifold
 ${\mathbb{R}}^n$
equipped with its standard parallelization (Ex. A.16).
Replacing a directed path by a directed smooth path of lesser length.

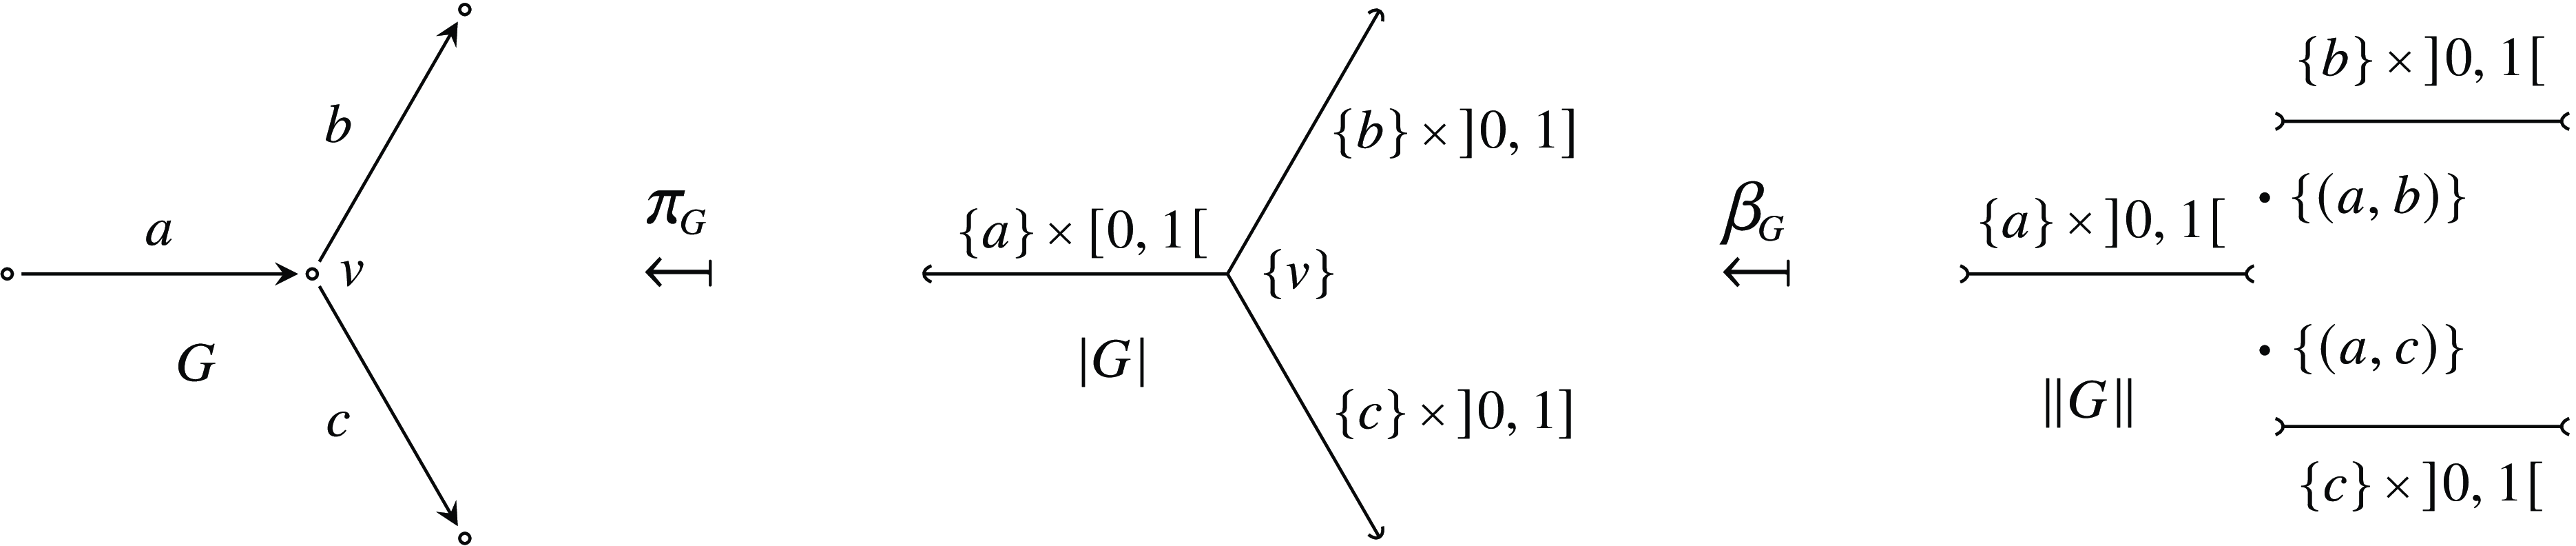
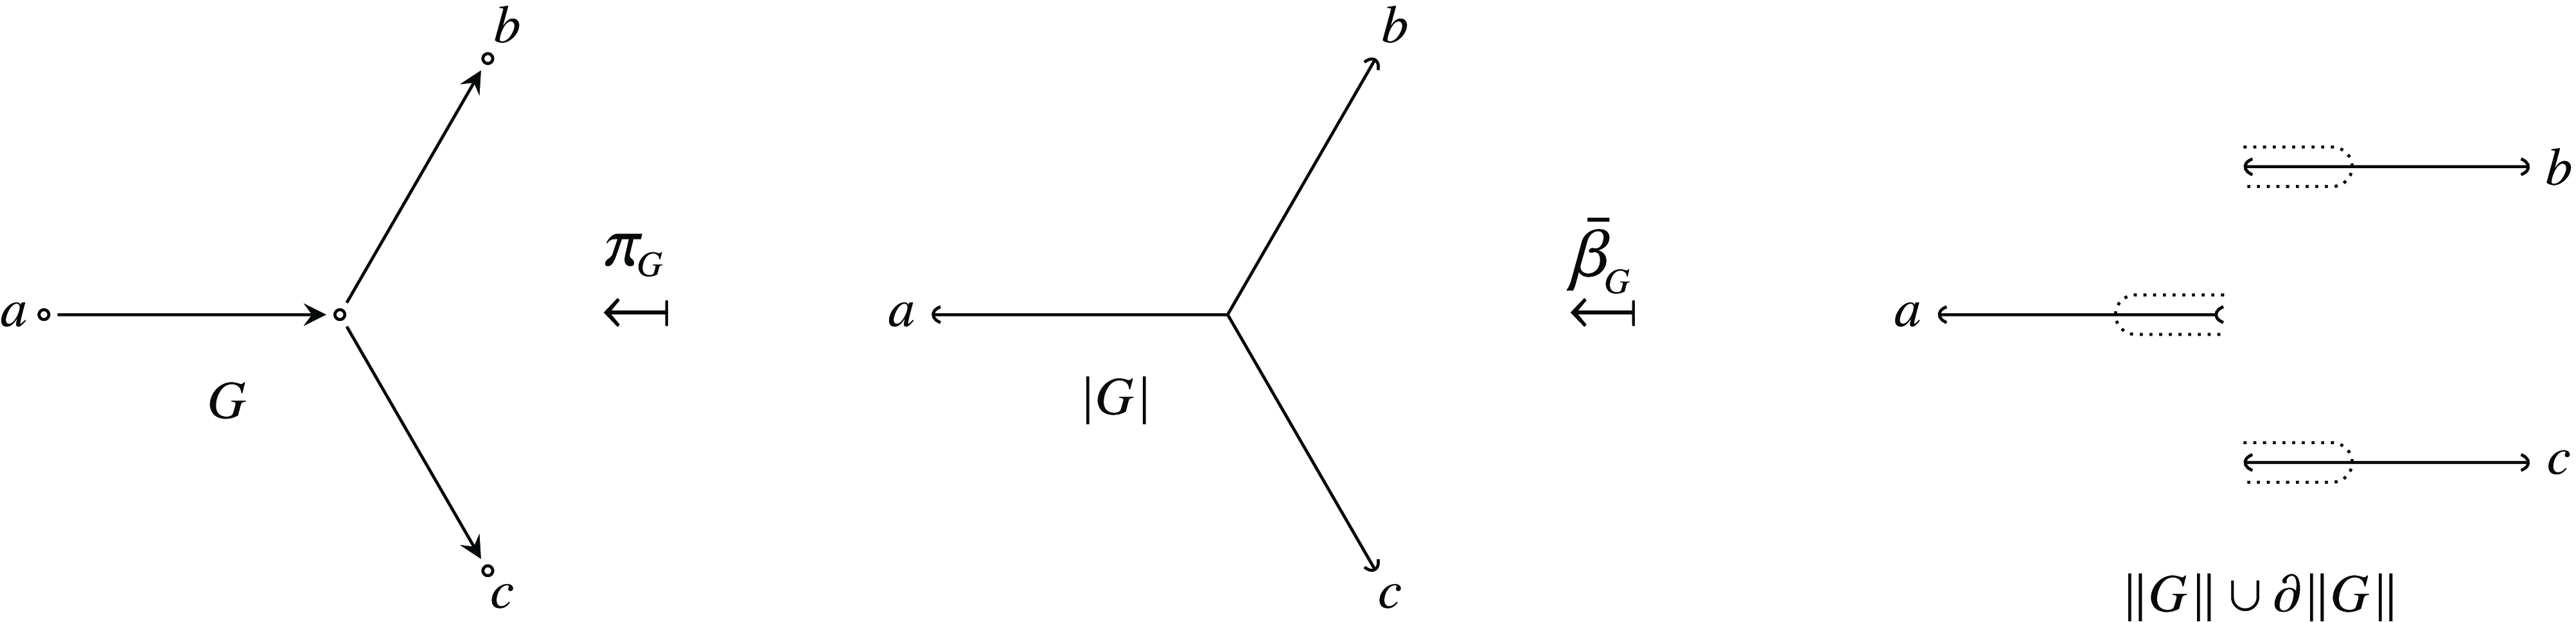
For a taste of what lies beyond progress graphs, assume that
 $G$
represents an «if-then-else» instruction (see Ex. 2.21):

The underlying set of the locally ordered metric graph
 $|{G}|$
is
 $V\cup A \times ]0,1[$
with
 $A$
and
 $V$
denoting the sets of arrows and vertices of the graph
 $G$
. At every point except for the four vertices of
 $G$
, which form a “neglectable” subset of
 $|{G}|$
, the local order is locally isomorphic to
 $\mathbb{R}$
. In order to get rid of these “singularities,” every vertex is “blown up” into as many points as there are ways of going through it in respect of the local order. Consequently, the vertex
 $v$
is duplicated and the extremities of
 $G$
are removed. The resulting set
 $\|{G}\|$
equipped with the adhoc (non-Hausdorff) topology often appears in textbooks as an undesirable
 $1$
-dimensional smooth manifold, see (Bishop and Crittenden Reference Bishop and Crittenden1964, p. 5, 6), (Lee Reference Lee2012, p. 4), or (Benedetti Reference Benedetti2021, p. 58). Such oddities are precisely what we need to consider in order to represent branchings.
1.2 Context
In geometry of concurrency, one associates every tuple of graphs
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
with a local order
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
(Def. 5.11) on the
 $\alpha$
-product of metric spaces
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
with
 $\alpha \in [{{1}},{{\infty }}]$
(Def. 4.17). A conservative program
 $P$
is a parallel composition
 ${{P}}_{1}{|}\cdots {|}{{P}}_{n}$
of sequential processes whose underlying graphs are
 ${{G}}_{{1},\ldots ,{{G}}_{n}}$
. The model of
 $P$
is a subset
 $|{P}|$
of
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
. Every directed path
 $\gamma$
on
 $|{P}|$
induces a sequence of multi-instructions
 $\sigma$
, which has a certain effect on the state of the abstract machine on which
 $P$
is executed; by extension, the effect of
 $\gamma$
is that of
 $\sigma$
. Two directed paths on
 $|{P}|$
that are sufficiently close to each other have the same effect (Haucourt Reference Haucourt2018, Thm. 6.1); we say that the model of
 $P$
is resilient.
1.3 Contribution
We introduce the blowup of a graph
 $G$
as a set map
 ${\beta }_G:\|{G}\|\to |{G}|$
(Def. 2.15) together with a (non-Hausdorff) atlas
 $\mathcal{A}_{{G}}$
on
 $\|{G}\|$
(Def. 3.3) and a non-vanishing vector field
 ${{f}}_{{{G}}}$
on
 $\mathcal{A}_{{G}}$
(Def. 3.6). We relate the parallelized atlas
 $({\mathcal{A}}_{{G_{1}}} \times \cdots \times {\mathcal{A}}_{G_{n}},{{f}}_{{{G_1}}},\ldots ,{{f}}_{{{G_n}}})$
to the local order
 $\mathcal{X}_{{G_{1}}} \times \cdots \times {\mathcal{X}}_{G_{n}}$
and its
 $\alpha$
-product metric by means of an intermediate local order
 $\tilde {\mathcal{X}}_{G_{1}} \times \cdots \times \tilde {\mathcal{X}}_{G_{n}}$
on
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
(Def. 5.15). More precisely, we prove that
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_{1}}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_{n}}}$
is the “best smooth approximation” of
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
(Thm. 5.33), and that every directed path on the image of
 ${{\beta }}_{{{G_{1}}}} \times \cdots \times {{\beta }}_{{{G_{n}}}}$
can be lifted to a directed path on
 $\tilde {\mathcal{X}}_{{G_{1}}} \times \cdots \times \tilde {\mathcal{X}}_{{G_{n}}}$
(Thm. 5.29). Then we prove that the local order
 $\tilde {\mathcal{X}}_{{G_{1}}} \times \cdots \times \tilde {\mathcal{X}}_{{G_{n}}}$
and the cone field generated by
 $({{f}}_{{{G_1}}},\ldots ,{{f}}_{{{G_n}}})$
can be deduced from each other (Thm. 5.41). The vector fields
 ${{f}}_{{{G_1}}},\ldots ,{{f}}_{{{G_n}}}$
canonically induce a notion of length for (piecewise) smooth paths on
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
(Def. 4.22) from which we deduce the
 $\alpha$
-product metric on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
(Thm. 4.26). If we take
 $\alpha =\infty$
, then the length of a directed path on
 $|{P}|$
is the execution time of its sequence of multi-instructions (§6.1). The resilience of
 $|{P}|$
together with Thm. 6.5 and Cor. 6.6 implies that every execution trace of
 $P$
can be represented by a piecewise affine-directed path.
1.4 Overview
The discrete and the continuous models of a conservative program
 $P$
are discussed in §2. In particular, every directed graph
 $G$
comes with a set theoretic map
 ${\beta }_G:\|{G}\|\to |{G}|$
which “blows up” every singularity of
 $|{G}|$
(Def. 2.15). The manifold and the local order to which the title refers are the standard atlas
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
with its standard parallelization (Def. 3.3 and 3.6), and the standard local order
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
(Def. 5.11); their underlying sets are
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
and
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
, respectively. The transition maps of
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
are translations (Lem. 3.2), which make the derivatives of smooth maps between standard atlases easy to represent (Rem. 3.9). The standard parallelization of
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
, which we denote by
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
, induces a local order
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_{1}}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_{n}}}$
on
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
, and the parallelization can be recovered from the local order (Def. 5.15 and Thm. 5.41); this result is based on an equivalence of categories due to (Lawson Reference Lawson1989, p. 283–284) (§5.4). The product map
 ${{\beta }}_{{{G_{1}}}} \times \cdots \times {{\beta }}_{{{G_{n}}}}$
satisfies a universal lifting property relating the local orders
 $\tilde {\mathcal{X}}_{G_{1}} \times \cdots \times \tilde {\mathcal{X}}_{G_{n}}$
and
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
(Thm. 5.33).
From every map
 $\ell :\{\text{arrows of $G$}\}\to \mathbb{R}_{{+}}$
admitting a positive lower bound, one defines a metric
 ${{d}}_{{{|{G}|}}}$
on the set
 $|{G}|$
; metric spaces of this form are called metric graphs – see (Bridson and Haefliger Reference Bridson and Haefliger1999, §1.9, p. 6–7) and (Papadopoulos Reference Papadopoulos2013, p. 43). As in (Haucourt Reference Haucourt2018, §6.2, p. 1745–1748), they are meant to replace intervals of
 $\mathbb{R}$
in view of modeling programs with branchings. Due to their prominent role (and because we have not found a presentation that fits our needs), we thoroughly describe these spaces in §4. For our purpose, we assume that
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
is equipped with the
 $\alpha$
-product metric
 ${{d}}^{{({\alpha })}}$
for some
 $\alpha \in [{{1}},{{\infty }}]$
(Def. B.11). If we wish
 $\alpha$
to be in accordance with the parallel execution time principle (§6.1), we should take
 $\alpha =\infty$
. We transport the
 $\alpha$
-norm on
 ${\mathbb{R}}^n$
to every tangent space of
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
through
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
and define the smoothed
 $\alpha$
-length
 $\mathcal{L}^{\alpha }(\gamma )$
of a piecewise smooth path
 $\gamma$
as the sum of the lengths of its tangent vectors (Def. 4.22). Assuming that
 $p$
and
 $q$
are the images of
 $p'$
and
 $q'$
under
 ${{\beta }}_{{{G_{1}}}} \times \cdots \times {{\beta }}_{{{G_{n}}}}$
, the distance
 ${{d}}^{{({\alpha })}}(p,q)$
is the infimum of
 $\mathcal{L}^{\alpha }(\gamma )$
for
 $\gamma$
piecewise smooth paths from
 $p'$
to
 $q'$
(Thm. 4.26). So for every
 $\alpha \in [{{1}},{{\infty }}]$
, the metric
 ${{d}}^{{({\alpha })}}$
derives from
 $\mathcal{L}^{\alpha }$
which derives from
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
.
From the computer science point of view, for
 $\varepsilon \gt 0$
sufficiently small, the sequences of mutli-instructions induced by a directed path and its
 $\varepsilon$
-approximations (Def. 6.1) lead to the same result (Haucourt Reference Haucourt2018, Thm. 6.1). Also, every directed path
 $\gamma$
on a tile-compatible subset
 $M$
of
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
(resp.
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
) admits a piecewise affine
 $\varepsilon$
-approximation on
 $M$
(Thm. 6.5, Cor. 6.6, and Def. 2.11). Since the geometric and the smooth models of a conservative program are tile compatible (Def. 2.13 and 2.22), any execution trace of the program to model can be represented by a piecewise affine path.
The main text is followed by two appendices. The first one (App. A) is dedicated to non-Hausdorff manifolds which are at the core of this article but rather unusual in mainstream mathematics (see p. 49). The second one (App. B) gathers some facts about length spaces expressed with the notations of this document, and taking into account its specifics.
2. Underlying Sets of Models
As we shall see in sections 3, 4, and 5, the continuous models of conservative programs inherit their structures from atlases, metrics, and local orders. We explicitly describe their underlying sets.
For the rest of the article, we write “graph” to mean “directed (multi)graph;” hence, a graph is a set
 $G$
, whose elements are called points, together with three maps, namely
 $\dim :G\to \{0,1\}$
, and
 $\textrm {src}, \textrm {tgt}:{{G}}^{{({1})}}\to {{G}}^{{({0})}}$
with
 ${{G}}^{{({\varepsilon })}}=\{x\in G\mid \dim x=\varepsilon \}$
for
 $\varepsilon \in \{0,1\}$
. These maps are, respectively, called dimension, source, and target. A vertex (resp. an arrow) is a point of
 $G$
of dimension
 $0$
(resp.
 $1$
). Given a vertex
 $v$
, an arrow
 $a$
is said to be incoming (resp. outgoing) when
 $\textrm {tgt}\; a=v$
(resp.
 $\textrm {src}\ a=v$
). A vertex with no incoming or no outgoing arrow is called an endpoint. We use the same denotation for the graph and its underlying set. A map
 $f:G\to G'$
is a morphism of graphs when it preserves dimensions, sources, and targets. The category of graphs is denoted by
 $\mathbf{Grph}$
.
The next definition is motivated by topological arguments (Haucourt Reference Haucourt2018, Lem. 6.1):
Definition 2.1 (Haucourt (Reference Haucourt2018), Def. 3.4). A directed path on a tuple of graphs
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
is a finite sequence
 ${{p}}_{{0},\ldots ,{{p}}_{k}}$
of points of
 ${{G}}_{1}{ \times }\cdots { \times }{{G}}_{n}$
satisfying
 \begin{equation} \left \{ \begin{array}{ll} {{\text{pr}}}_{{{i}}}({{p}}_{{{j}}}) \not = {{\text{pr}}}_{{{i}}}({{p}}_{{{j-1}}})\:\:\Rightarrow \:\textrm {src}({{\text{pr}}}_{{{i}}}({{p}}_{{{j}}})) = {{\text{pr}}}_{{{i}}}({{p}}_{{{j-1}}}), & \text{for every }i\in \{{1},\ldots ,{n}\} \\[2mm] \text{or} \\[2mm] {{\text{pr}}}_{{{i}}}({{p}}_{{{j}}}) \not = {{\text{pr}}}_{{{i}}}({{p}}_{{{j-1}}})\:\:\Rightarrow \:\:{{\text{pr}}}_{{{i}}}({{p}}_{{{j}}}) = \textrm {tgt}({{\text{pr}}}_{{{i}}}({{p}}_{{{j-1}}})), & \text{for every }i\in \{{1},\ldots ,{n}\} \end{array} \right . \end{equation}
for every
 $j\in \{{1},\ldots ,{k}\}$
with
 ${{\text{pr}}}_{{{i}}}:{{G}}_{1}{ \times }\cdots { \times }{{G}}_{n}\to {{G}}_{{{i}}}$
denoting the
 $i^{th}$
projection. In the first (resp. second) case of (
1
), we say that the
 $j^{th}$
step of the directed path raises (resp. lowers) dimension.
2.1 Discrete models of conservative programs
The notion of a conservative program (Haucourt Reference Haucourt2018, §4.1) is based on a virtual machine allowing parallel execution of multi-instructions, that is, partial maps
 $\mu$
on
 $\{{1},\ldots ,{n}\}$
assigning to the
 $i^{th}$
process of the machine the instruction it has to execute (the
 $i^{th}$
process is inactive during the execution of
 $\mu$
if the latter is not defined at
 $i$
). Every instruction executed by
 $\mu$
is supposed to be atomic in the sense that «its execution should appear to take effect instantaneously at some moment between its invocation and response» (Herlihy et al. Reference Herlihy, Shavit, Luchangco and Spear2020, Principle 3.4.1, p. 58).
Definition 2.2.
A sequential process is a graph
 $G$
whose arrows are labeled with atomic instructions. We suppose that every vertex of
 $G$
with at least two outgoing (resp. incoming) arrows has at least one incoming (resp. outgoing) arrow; this assumption is used exactly once, but crucially, in the proof of Lem. 4.25
. A program
 $P$
is an
 $n$
-tuple (
 $n\in \mathbb{N}$
) of sequential processes running concurrently (if
 $n=1$
then
 $P$
is just a sequential process). We write
 $P={{P}}_{1}{\mid }\cdots {\mid }{{P}}_{n}$
to mean that
 ${{P}}_{{{i}}}$
is the
 $i^{th}$
process of
 $P$
with
 $i\in \{{1},\ldots ,{n}\}$
, and we denote by
 ${{G}}_{{{i}}}$
the underlying graph of
 ${{P}}_{{{i}}}$
. Hence,
 $P$
is associated with the
 $n$
-tuple of graphs
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
.
With the notation from Def. 2.2, the vertices of
 $G$
are possible positions of the instruction pointer
 $p$
. At each step,
 $p$
moves from the source
 $v$
to the target
 $v'$
of the arrow
 $a$
carrying the next instruction to execute. However, our setting does not allow
 $p$
to jump from
 $v$
to
 $v'$
without going through an intermediate stage, namely the arrow
 $a$
itself. The arrows of
 $G$
are thus legit positions of the instruction pointer; we are in a setting where instruction executions, or more abstractly “events,” have duration (Pratt Reference Pratt2000, §4, §5).
The virtual machine on which
 $P$
is executed comes with a pool of resources shared by the processes of
 $P$
. These resources are renewable in the sense that they can be restored after use: each process can take and release them by means of atomic instructions.
Definition 2.3.
Let
 ${{p}}_{{0},\ldots ,{{p}}_{k}}$
be a directed path on the tuple of graphs
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
(Def. 2.1) associated to
 $P$
(Def. 2.2). For
 $j\in \{{1},\ldots ,{k}\}$
, we denote by
 ${{\mu }}_j$
the multi-instruction that is executed when the instruction pointer moves from
 ${{p}}_{{{j-1}}}$
to
 ${{p}}_{{{j}}}$
: if the
 $j^{th}$
step raises (resp. lowers) dimension (Def. 2.1), then the indices
 $i$
such that
 ${{\text{pr}}}_{{{i}}}({{p}}_{{{j}}}) \not = {{\text{pr}}}_{{{i}}}({{p}}_{{{j-1}}})$
are those of the processes that start (resp. finish) the execution of an atomic instruction. By an abuse of language, we write “the execution of the directed path
 ${{p}}_{{0},\ldots ,{{p}}_{k}}$
” to refer to the execution of the sequence of multi-instructions
 ${{\mu }}_{{1},\ldots ,{{\mu }}_{k}}$
. An execution trace of
 $P$
is a directed path on
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
whose execution respects conditional branchings (Haucourt Reference Haucourt2018
, p. 1729).
Definition 2.4 (Haucourt (Reference Haucourt2018), Def. 4.1). The program
 $P$
is said to be conservative when the amount of resources mobilized after the execution of any directed path
 ${p}_{{0},\ldots ,{p}_{k}}$
on
 $({G}_{{1},\ldots ,{G}_{n}})$
only depends on
 ${p}_{{0}}$
and
 ${p}_{{k}}$
.
A program
 $P$
is conservative if, and only if, so are its processes (Haucourt Reference Haucourt2018, Lem. 4.1). Whether a sequential process is conservative is decided by a breadth-first traversal of its underlying graph (Haucourt Reference Haucourt2018, p. 1734–1735).
Definition 2.5.
For the purposes of our study, we only need to know that the discrete model of a conservative program
 $P$
(Haucourt Reference Haucourt2018
, §4.2) is a subset
 ${{[[{{P}}]]}}_{{{d}}}$
of the product of sets
 ${{G}}_{1}{ \times }\cdots { \times }{{G}}_{n}$
satisfying the following properties:
-
(1) If the virtual machine fulfills the resource requirements specified in
$P$
, then any directed path on
${{[[{{P}}]]}}_{{{d}}}$
(Def. 2.1) induces a sequence of multi-instructions that the virtual machine can execute without exhausting its pool of resources.
-
(2) For every execution trace of
$P$
, there exists a directed path on
${{[[{{P}}]]}}_{{{d}}}$
with the same sequence of multi-instructions (Haucourt Reference Haucourt2018
, Thm. 4.1).


In other words, the amount of resources required to execute a conservative program
 $P$
is known at compile time. Moreover, according to the second point of Def. 2.5, the discrete model of
 $P$
induces an overapproximation of all its possible behaviors (i.e. all the sequences of multi-instructions associated with the execution traces of
 $P$
); the subtlety is that multiple directed paths on
 $({{G}}_{{1},\,\ldots ,\, {{G}}_{n}})$
may induce the same sequence of multi-instructions.
2.2 Continuum of states
We have already mentioned that the arrows of the graph of a sequential process are intermediate positions of the instruction pointer (Def. 2.2). Pushing this principle further, we specify where the pointer stands on a given arrow of
 $G$
. Suppose that the map
 \begin{equation*} \ell \::\:{{G}}^{{({1})}}\:\to \:\:[{{R}},{{\infty }}[ \end{equation*}
assigns to each arrow a length which is meant to be the execution time of the atomic instruction it carries (§6). The real number
 $R$
is supposed to be positive because execution times should not be arbitrarily small. This constraint has important consequences for the mathematical properties of the models that will be defined later. We end up with a continuum of states:
Definition 2.6.
The underlying set of the metric graph of
 $G$
is the set
 \begin{equation*} |{G}| = {{G}}^{{({0})}} \:\: \cup \:\: \bigcup \big \{\:\:\{a\} \times ]{{0}},{{\ell (a)}}[\:\:\ \big |\ \:\:a\in {{G}}^{{({1})}}\:\:\big \} . \end{equation*}
The quotient map
 ${{\pi }}_G:|{G}|\to G$
is defined by
 ${{\pi }}_G(v)=v$
on
 ${{G}}^{{({0})}}$
and by
 ${{\pi }}_G(a,t)=a$
elsewhere. The local order on
 $|{G}|$
(Def. 5.11) encodes the constraints that force the pointer
 $p$
to move continuously with respect to the direction imposed by the arrows. The source and the target of an arrow
 $a$
play the role of
 $(a,0)$
and
 $(a,\ell (a))$
which are intentionally omitted. An arrow of
 $|{G}|$
is a subset of the form
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
for some
 $a\in {{G}}^{{({1})}}$
; by extension its source and its target are those of
 $a$
.
Definition 2.7.
Subsets of the form
 $\{a\} \times J$
are said to be initial (resp. final) when
 $J$
is an initial (resp. final) subinterval of
 $]{{0}},{{\ell (a)}}[$
. A subset
 $S$
of
 $|{G}|$
is said to be a star when it is of the form
 \begin{equation*} S(v,i,f) = \bigcup _{\textrm {tgt}\; a=v}\{a\} \times ]{{\ell (a)-f(a)}},{{\ell (a)}}[ \quad \cup \quad \{v\} \quad \cup \:\:\bigcup _{\textrm {src}\ a=v}\{a\} \times ]{{0}},{{i(a)}}[ \end{equation*}
with the functions
 $i:{{\textrm {src}}}^{{-1}}\{v\}\to \mathbb{R}_{{+}}\setminus \{0\}$
,
 $f:{{\textrm {tgt}}}^{{-1}}\{v\}\to \mathbb{R}_{{+}}\setminus \{0\}$
satisfying
 $i(a)$
,
 $f(a)\leqslant \ell (a)$
whenever it makes sense. The vertex
 $v$
is called the center of the star. Moreover:
-
– we write
$S(v)$
when
$i(a)=\ell (a)$
and
$f(a)=\ell (a)$
whenever it makes sense.
-
– if both
$i$
and
$f$
are constant and equal to
$r\lt \tfrac R2$
, we write
$S(v,r)$
instead of
$S(v,i,f)$
, and call
$S(v,r)$
the star centered at
$v$
of radius
$r$
. -
– the canonical star centered at
$v$
is the set
$S(v,\tfrac \ell 2,\tfrac \ell 2)$
, that is,
$i(a)={\ell (a)}/2$
for every
$a\in {{\textrm {src}}}^{{-1}}\{v\}$
and
$f(a)={\ell (a)}/2$
for every
$a\in {{\textrm {tgt}}}^{{-1}}\{v\}$
.


Definition 2.8.
A segment of
 $G$
centered at
 $(a,t)$
with
 $a\in {{G}}^{{({1})}}$
and
 $t\in \:]{{0}},{{\ell (a)}}[$
, is a subset of
 $|{G}|$
of the form
 $\{a\} \times ]{{t-\varepsilon }},{{t+\varepsilon }}[$
with
 $\varepsilon \leqslant \min (t,\ell (a)-t)$
.
Remark 2.9.
The intersection of two stars is either a star or a (possibly empty) disjoint union of segments. The intersection of a segment with a star (resp. a segment) is either a segment, the union of two disjoint segments, or empty. Stars and segments thus form a base of a topology
 $\mathcal T$
on
 $|{G}|$
. The stars centered at
 $v$
(resp. the segments centered at
 $(a,t)$
) form a base of neighborhoods of
 $v$
(resp.
 $(a,t)$
). We give some immediate consequences: the topology
 $\mathcal T$
is Hausdorff; for every arrow
 $a$
the boundary of
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
is
 $\{\textrm {src}\ a,\textrm {tgt}\; a\}$
; for every vertex
 $v$
the boundary of
 $S(v)$
is the set
 $\{\textrm {src}(a),\textrm {tgt}(a)\mid a\in {{G}}^{{({1})}},\:v\in \{\textrm {src}(a),\textrm {tgt}(a)\}\}\setminus \{v\}$
; and the connected components of
 $|{G}|\setminus {{G}}^{{({0})}}$
are the segments
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
for
 $a$
arrow of
 $G$
.
Definition 2.10.
The topology of
 $|{G}|$
is the topology
 $\mathcal T$
described in Rem. 2.9
; the geometric realization of
 $G$
is the topological space
 $(|{G}|,\mathcal T)$
.
A path on a topological space
 $X$
is a continuous map
 $\gamma :[{{a}},{{b}}]\to X$
with
 $a\leqslant b$
. The endpoints of
 $\gamma$
are
 $\gamma (a)$
and
 $\gamma (b)$
, more precisely its starting and finishing points. The opposite of
 $\gamma$
is the path
 $\bar {\gamma }:[{{a}},{{b}}]\to X$
with
 $\bar {\gamma }(t)=\gamma (a+b-t)$
. Given a path
 $\delta :[{{b}},{{c}}]\to X$
with
 $\gamma (b)=\delta (b)$
, the concatenation
 $\gamma \cdot \delta$
is the path defined on
 $[{{a}},{{c}}]$
by
 $\gamma \cdot \delta (t)=\gamma (t)$
if
 $t\leqslant b$
, and by
 $\gamma \cdot \delta (t)=\delta (t)$
if
 $b\leqslant t$
. If
 $\textit {dom}\:(\delta )=[{{b'}},{{c}}]$
, then we still write
 $\gamma \cdot \delta$
to mean
 $\gamma \cdot (\delta \circ \tau )$
with
 $\tau$
denoting the translation
 $t\mapsto t+b'-b$
from
 $[{{b}},{{c-b'+b}}]$
to
 $[{{b'}},{{c}}]$
.
Definition 2.11.
The tile over
 $p\in {{G}}_{1}{ \times }\cdots { \times }{{G}}_{n}$
is the set
 ${{({{\pi }}_{G_1}{ \times }\cdots { \times }{{\pi }}_{G_n})}}^{{-1}}\{p\}$
, that is,
 ${{\tau }}_{1}{ \times }\cdots { \times }{{\tau }}_{n}$
with
 ${{\tau }}_i=\{{{p}}_{{{i}}}\}$
if
 ${{p}}_{{{i}}}$
is a vertex, and
 ${{\tau }}_i=\{{{p}}_{{{i}}}\} \times ]{{0}},{{\ell ({{p}}_{{{i}}})}}[$
if
 ${{p}}_{{{i}}}$
is an arrow. Each
 ${{\tau }}_i$
admits a canonical (total) order; the product of these total orders is the canonical partial order of the tile over
 $p$
. A path
 $\gamma$
on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
is said to be directed when for every tile
 $\tau$
and every interval
 $J\subseteq {{\gamma }}^{{-1}}(\tau )$
, the restriction of
 $\gamma$
to
 $J$
is order preserving; we say that
 $\gamma$
crosses a tile
 $\tau$
if there exists
 $[{{a}},{{b}}]\subseteq \textit {dom}\:(\gamma )$
such that
 $\gamma ([{{a}},{{b}}])\subseteq \bar {\tau }$
(the closure of
 $\tau$
) and
 $\gamma ([{{a}},{{b}}])\setminus \tau =\{\gamma (a),\gamma (b)\}$
. A subset of
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
is said to be tile compatible when it can be written as a (necessarily disjoint) union of tiles. The middle of the tile over
 $p$
is the point
 $({{x}}_{{1},\ldots ,{{x}}_{n}})$
defined by
 \begin{equation*} {{x}}_{{{i}}} = \left \{\begin{array}{ll} {{p}}_{{{i}}} & \text{ if } {{p}}_{{{i}}} \text{ is a vertex,} \\ \big ({{p}}_{{{i}}},\tfrac 12\ell ({{p}}_{{{i}}})\big ) & \text{ if } {{p}}_{{{i}}} \text{ is an arrow,} \\ \end{array} \right . \end{equation*}
for
 $i\in \{{1},\ldots ,{n}\}$
. The lower corner and the upper corner of the tile over
 $p$
are the points
 $({{x}}_{{1},\ldots ,{{x}}_{n}})$
and
 $({{y}}_{{1},\ldots ,{{y}}_{n}})$
defined, for
 $i\in \{{1},\ldots ,{n}\}$
, by
 \begin{equation*} {{x}}_{{{i}}} = \left \{ \begin{array}{ll} {{p}}_{{{i}}} & \text{ if } {{p}}_{{{i}}} \text{ is a vertex,} \\ \textrm {src}({{p}}_{{{i}}}) & \text{ if } {{p}}_{{{i}}} \text{ is an arrow} \\ \end{array} \right . \qquad \text{and}\qquad {{y}}_{{y}{{i}}} = \left \{ \begin{array}{ll} {{p}}_{{{i}}} & \text{ if } {{p}}_{{{i}}} \text{ is a vertex,} \\ \textrm {tgt}({{p}}_{{{i}}}) & \text{ if } {{p}}_{{{i}}} \text{ is an arrow.} \\ \end{array} \right . \end{equation*}
Note that if one of the components of
 $p$
is an arrow, then the source and the target of
 $p$
do not belong to the tile over
 $p$
.
Remark 2.12.
With the notation from Def. 2.11
, it follows from Def. 2.10 that the closure of a tile
 $\tau$
over
 $p$
, which we denote by
 $\bar {\tau }$
, is the set of points
 $({{x}}_{{1},\ldots ,{{x}}_{n}})$
such that for
 $i\in \{{1},\ldots ,{n}\}$
we have
 ${{x}}_{{{i}}}={{p}}_{{{i}}}$
if
 ${{p}}_{{{i}}}$
is a vertex, and
 ${{x}}_{{{i}}}\in \{{{p}}_{{{i}}}\} \times ]{{0}},{{\ell ({{p}}_{{{i}}})}}[\:\cup \:\{\textrm {src}({{p}}_{{{i}}}),\textrm {tgt}({{p}}_{{{i}}})\}$
if
 ${{p}}_{{{i}}}$
is an arrow. In particular,
 $\bar {\tau }$
is tile compatible; this property is related to the frontier condition in the theory of stratified spaces (Pflaum Reference Pflaum2001
, p. 15), (Nocera and Volpe Reference Nocera and Volpe2023
, Def. 2.5).
The progress graphs shown in Figure 1 are tile compatible, and more generally:
Definition 2.13.
(Haucourt Reference Haucourt2018
, Def. 6.3). The underlying set of the geometric model of
 $P$
, which we denote by
 $|{P}|$
, is the set
 ${{({{\pi }}_{G_1}{ \times }\cdots { \times }{{\pi }}_{G_n})}}^{{-1}}{{[[{{P}}]]}}_{{{d}}}$
with
 ${{[[{{P}}]]}}_{{{d}}}$
denoting the discrete model of
 $P$
(Def. 2.5); it is tile compatible.
The notion of tile compatibility deserves some explanation. Every
 $p\in {{[[{{P}}]]}}_{{{d}}}$
is (tacitly) labeled by the multi-instruction
 $\mu$
that is defined at
 $i$
when
 ${{p}}_{{{i}}}$
is an arrow of
 ${{G}}_{{{i}}}$
(the underlying graph of the
 $i^{th}$
process of
 $P$
), in which case the (atomic) instruction
 ${{\mu }}_i$
is the label of
 ${{p}}_{{{i}}}$
– see Def. 2.2. Denote by
 ${{\tau }}_p$
the tile over
 $p$
, and let
 $\gamma$
be a directed path (Def. 2.11) from the lower corner to the upper corner of
 ${{\tau }}_p$
which only visits
 ${{\tau }}_p$
and its corners. Then,
 $\gamma$
represents an execution of the multi-instruction
 $\mu$
in which the speeds of the processes may vary independently of each other, with the only restriction that all the processes start and finish at the same time. From this point of view, the tile over
 $p$
represents all the possible continuous schedules for the execution of
 $\mu$
(by contrast, there is only one discrete schedule for the execution of
 $\mu$
). A more elaborate discussion should take into account all the directed paths
 $\gamma$
that cross
 ${{\tau }}_p$
(Def. 2.11). Suppose that
 $[{{a}},{{b}}]\subseteq \textit {dom}\:(\gamma )$
with
 $\gamma ([{{a}},{{b}}])\subseteq {{\bar {\tau }}}_{{{p}}}$
and
 $\gamma ([{{a}},{{b}}])\setminus {{\tau }}_p=\{\gamma (a),\gamma (b)\}$
. Also suppose that
 $\gamma$
is written as the concatenation
 ${{\gamma }}_{{{1}}}{{\gamma }}_{{{2}}}{{\gamma }}_{{{3}}}$
with
 ${{\gamma }}_{{{2}}}$
the restriction of
 $\gamma$
to
 $[{{a}},{{b}}]$
. As long as one is only concerned with the execution trace associated with
 $\gamma$
, one can “replace”
 $\gamma$
by
 $\delta ={{\gamma }}_{{{1}}}{{\tilde \gamma }}_{{{2}}}{{\gamma }}_{{{3}}}$
provided that
 ${{\tilde \gamma }}_{{{2}}}$
is a directed path defined on
 $[{{a}},{{b}}]$
with
 ${{\tilde \gamma }}_{{{2}}}(a)=\gamma (a)$
,
 ${{\tilde \gamma }}_{{{2}}}(b)=\gamma (b)$
, and
 ${{\tilde \gamma }}_{{{2}}}(]{{a}},{{b}}[)\subseteq {{\tau }}_p$
– see (Haucourt, Reference Haucourt2018, Thm. 6.1 and Cor. 6.2) for a formal statement. It may be that
 $\delta$
is smooth while
 $\gamma$
is not, and the path
 $\delta$
may be of lesser length – see Figure 2. If
 $X$
is a tile-compatible subset of
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
, then we have
 $\textit {img}\:(\gamma )\subseteq X\Leftrightarrow \textit {img}\:(\delta )\subseteq X$
. Consequently, in a tile-compatible set, one can choose the directed path representing a given execution trace in order to optimize certain parameters: the cases of smoothness and execution time are discussed in §6, and more specifically in Thm. 6.5 and Cor. 6.6. Tile-compatible subsets also play an crucial role in the preamble of §5.
2.3 Blowing up vertices
For every arrow
 $a$
of
 $G$
, the canonical bijection
 $\{a\} \times ]{{0}},{{\ell (a)}}[\to ]{{0}},{{\ell (a)}}[$
induces a dihomeomorphism (i.e. a homeomorphism i.e., also an order isomorphism, see p. 21).
Definition 2.14.
A traversal at
 $v$
is an ordered pair of arrows
 $(a,b)$
such that
 $\textrm {tgt}\; a=v=\textrm {src}\; b$
, we say that
 $v$
is regular when there is exactly one traversal at
 $v$
in
 $G$
; otherwise
 $v$
is said to be singular. By extension, the traversal
 $(a,b)$
is said to be regular (resp. singular) when so is
 $v$
.
From the topological and order-theoretic points of view, the set
 $|{G}|$
is “almost everywhere” like
 $\mathbb{R}$
. The only possible exceptions are the singular vertices of
 $G$
. As for curves in Algebraic Geometry,Footnote
1
we “resolve singularities” by “blowing them up,” that is, we replace each vertex
 $v$
by the traversals at
 $v$
:
Definition 2.15.
The underlying set of the blowup of
 $G$
, which we denote by
 $\|{G}\|$
, is the union of
 $|{G}|\setminus {{{G}}^{{({0})}}}$
and the set of traversals of
 $G$
, that is to say
 \begin{equation*} \|{G}\| = \bigcup \big \{\{a\} \times ]{{0}},{{\ell (a)}}[\ \big |\ {a\in {{G}}^{{({1})}}}\big \} \:\cup \: \big \{(a,b)\in {{G}}^{{({1})}} \times {{G}}^{{({1})}}\ \big |\ \textrm {tgt}\; a=\textrm {src}\; b\big \}. \end{equation*}
The blowup of
 $G$
is the map
 ${\beta }_G:\|{G}\|\to |{G}|$
defined by
 ${\beta }_G(a,b)=\textrm {tgt}\; a$
(or
 $\textrm {src}\; b$
) for every traversal
 $(a,b)$
of
 $G$
, and by
 ${\beta }_G(a,t)=(a,t)$
for every
 $a\in {{G}}^{{({1})}}$
and
 $t\in \:]{{0}},{{\ell (a)}}[$
. A subset of
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
is said to be tile compatible when it is the inverse image under
 ${{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}}$
of some tile-compatible set (Def. 2.11). From now on, we write
 ${{\beta }}_i$
instead of
 ${{\beta }}_{{{G_i}}}$
.
Remark 2.16.
The image of
 ${\beta }_G$
is precisely
 $|{G}|\setminus \{\text{endpoints of }G\}$
(see p. 5).
Remark 2.17.
The constructions
 $|{\_}|$
and
 $\|{\_}\|$
readily extend to functors from
 $\mathbf{Grph}$
to
 $\mathbf{Set}$
: given a graph morphism
 $f:G\to G'$
, the maps
 $|{f}|$
and
 $\|{f}\|$
are defined by
 \begin{equation*} |{f}|(v)={{f}}^{{({0})}}(v), \quad \|{f}\|(a,b)=({{f}}^{{({1})}}(a),{{f}}^{{({1})}}(b)), \quad \text{and}\quad |{f}|(a,t)=\|{f}\|(a,t)=({{f}}^{{({1})}}(a),t) \end{equation*}
where
 $v\in {{G}}^{{({0})}}$
,
 $a\in {{G}}^{{({1})}}$
,
 $t\in \:]{{0}},{{\ell (a)}}[$
,
 $(a,b)$
is a traversal of
 $G$
, and
 ${{f}}^{{({0})}}$
,
 ${{f}}^{{({1})}}$
denote the vertex and the arrow parts of
 $f$
. Moreover, the collection of blowups
 ${\beta }_G:\|{G}\|\to |{G}|$
, for
 $G$
running through the class of graphs, forms a natural transformation from
 $\|{\_}\|$
to
 $|{\_}|$
. If
 $|{G}|$
and
 $|{G'}|$
are equipped with the topologies from Rem. 2.9
, then
 $|{f}|$
is continuous.
Remark 2.18.
It is natural to define the topology of
 $\|{G}\|$
as the initial topology of the blowup
 ${\beta }_G$
: a base of this topology is given by the inverse images under
 ${\beta }_G$
of the stars and segments (Rem. 2.9). By observing that
 ${{{\beta }_G}}^{{-1}}(S(v,i,f))$
is the set
 \begin{equation*} \bigcup _{\textrm {tgt}\; a=v=\textrm {src}\; b}\{a\} \times ]{{\ell (a)-f(a)}},{{\ell (a)}}[ \:\:\cup \:\: \{(a,b)\} \:\cup \: \{b\} \times ]{{0}},{{i(b)}}[ \end{equation*}
we conclude that if the graph
 $G$
has a singular traversal
 $\tau$
(Def. 2.14), then the topology of
 $\|{G}\|$
is not
 ${{T}}_{{{1}}}$
; indeed, the set
 $\{\tau \}$
is not closed. Conversely, if
 $G$
has no singular traversal, then the topology of
 $\|{G}\|$
is Hausdorff (
 ${{T}}_{{{2}}}$
).
Lemma 2.19.
The image of a tile-compatible set (in the sense of Def. 2.15) under
 ${{\beta }}_{1}{ \times }\cdots { \times }{{\beta }}_{n}$
is tile compatible (in the sense of Def. 2.11).
Proof.
Suppose that
 $Y={{({{\beta }}_{1}{ \times }\cdots { \times }{{\beta }}_{n})}}^{{-1}}X$
for some tile-compatible set
 $X$
and that
 $q\in Y\cap {{({{\beta }}_{1}{ \times }\cdots { \times }{{\beta }}_{n})}}^{{-1}}\tau$
for some tile
 $\tau$
. Let
 $p\in \tau$
. We have
 $({{\beta }}_{1}{ \times }\cdots { \times }{{\beta }}_{n})(q)\in X$
, therefore
 $\tau \subseteq X$
because
 $X$
is tile compatible; hence
 $p\in X$
. For
 $i\in \{{1},\ldots ,{n}\}$
, if
 ${{q}}_{{{i}}}$
is a traversal, then put
 ${{q'}}_{{{i}}}={{q}}_{{{i}}}$
; otherwise
 ${{q'}}_{{{i}}}={{p}}_{{{i}}}$
. Then
 $({{\beta }}_{1}{ \times }\cdots { \times }{{\beta }}_{n})(q')=p$
.
Example 2.20.
We denote by
 $Z$
the connected graph whose arrows (all of length
 $1$
) are
 $(n,n+1)$
with
 $n\in \mathbb{Z}$
, the source and the target being
 $n$
and
 $n+1$
, respectively.

Every vertex of
 $Z$
has a unique traversal so the blowup of
 $Z$
is a bijection. We obtain a canonical bijection from
 $\|{Z}\|$
to
 $\mathbb{R}$
by composing the blowup of
 $Z$
with the following bijection:
 \begin{equation*} \begin{array}{ccl} |{Z}| & \to & {\mathbb{R}} \\ n & \mapsto & n \\ ((n,n+1),t) &\mapsto & n+t \end{array} \end{equation*}
Example 2.21.
Fig.
3
describes the blowup of a graph
 $G$
whose arrows are of length
 $1$
, and which contains a branching point
 $v$
; for the sake of readability, we have identified
 $\textrm {src}\ a$
,
 $\textrm {tgt}\ b$
, and
 $\textrm {tgt}\ c$
with
 $(a,0)$
,
 $(b,1)$
, and
 $(c,1)$
in the representation of
 $|{G}|$
(compare with Def. 2.6).
The blowup of a graph containing a branching point.

We will see that every set
 $\|{G}\|$
carries a “canonical” atlas (Def. 3.3). Connectedness and non-Hausdorffness of (the topology of) this atlas (Def. A.8) derive from the fact that any neighborhood of a traversal
 $(a,b)$
meets any neighborhood of another traversal
 $(a',b')$
precisely when
 $a=a'$
or
 $b=b'$
(see the proof of Lem. 3.2).
We have already observed that the endpoints of
 $G$
are “forgotten” by
 $\|{G}\|$
. One may think of this as an issue since the starting point of the automaton associated with a process is an endpoint. We circumvent the difficulty taking advantage of the following control flow graph feature: the starting point has a unique outgoing arrow
 $a$
(Def. 2.2). So we can harmlessly declare any point on
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
to be the starting point instead of the source of
 $a$
. Another (and more canonical) way to solve the problem consists of adding a fresh arrow ending at the starting point we wish to save. The same remarks hold (and the same tricks work) for the final points of the graph.


3. Differential Calculus On Standard Atlases
In differential geometry, manifolds are equivalence classes of atlases (Def. A.4). Such a class contains a maximal element (with respect to inclusion) with which the manifold is usually identified. However, each manifold we will meet in this article comes with a canonical representative that is much more tractable than the maximal one. Indeed, the representation of any tangent vector in a standard atlas (Def. 3.3) does not depend on the standard chart (Def. 3.1) in which it is represented. Consequently, smooth maps between standard atlases are handled (almost) as smooth maps between open subsets of Euclidean spaces. For this reason, we only deal with atlases (App. A).
We are not concerned with global properties of manifolds, so we can harmlessly let them be non-Hausdorff.Footnote 2 This seemingly anodyne weakening is of crucial importance here for it allows branchings (Ex. 2.21), which is precisely what we need to build manifolds from graphs, see Def. 3.3 and Rem. 3.5. The relation between non-Hausdorff manifolds, branching, non-determinism, and bifurcation is well-known (Müller (Reference Müller2013)). Such manifolds naturally appear in the study of dynamical systems (Goel (Reference Goel1987)), foliations of the plane (Haefliger and Reeb (Reference Haefliger and Reeb1957)), (Hirsch Reference Hirsch1976, 11., p. 15), (Gauld, Reference Gauld2014, Chap. 9), and general relativity (Hájíček (Reference Hájíček1971a,Reference Hájíčekb); Luc and Placek (Reference Luc and Placek2020)). The novelty is that we use non-Hausdorff manifolds to formalize the idea that a graph is a kind of “discrete vector field” (Def. 3.6).
3.1 Standard atlases
Given a graph
 $G$
with
 $\ell :{{G}}^{{({1})}}\to ]{{0}},{{\infty }}[$
, the set
 $\|{G}\|$
(Def. 2.15) admits a “natural” atlas that we now describe. Given
 $x\in {{G}}^{{({1})}}$
we define
 \begin{equation} {{I}}_{{{x}}}=\:\:]{{0}},{{\tfrac {\ell (x)}2}}[,\qquad {{J}}_{{{x}}}=\:\:]{{\tfrac {\ell (x)}2}},{{\ell (x)}}[, \end{equation}
and keep in mind the bijection
 $t \mapsto t-\ell (x)$
from
 ${{J}}_{{{x}}}$
to
 $-{{I}}_{{{x}}}$
.
Definition 3.1.
The standard charts of
 $G$
are the bijections
 \begin{equation*} \begin{gathered} {{\phi }}_{a\phantom {b}}\quad :\quad \{a\} \times ]{{0}},{{\ell (a)}}[\quad \to \quad ]{{0}},{{\ell (a)}}[\quad \text{and}\quad \\[1mm] {{\phi }}_{{{ab}}}\quad :\quad \{a\} \times {{J}}_{{{a}}}\:\:\cup \:\:\{(a,b)\}\:\:\cup \:\:\{b\} \times {{I}}_{{{b}}} \quad \to \quad -{{I}}_{{{a}}}\:\cup \:\{0\}\:\cup \:{{I}}_{{{b}}}\\[1mm] \quad \text{ with }\quad (a,t)\mapsto t-\ell (a), \quad (a,b)\mapsto 0, \quad (b,t)\mapsto t \end{gathered} \end{equation*}
for all arrows
 $a$
and all traversals
 $(a,b)$
of
 $G$
. The standard charts of
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
are the products
 ${{\phi }}_{1}{ \times }\cdots { \times }{{\phi }}_{n}$
with
 ${{\phi }}_i$
a standard chart of
 ${{G}}_{{{i}}}$
for
 $i\in \{{1},\ldots ,{n}\}$
.
Lemma 3.2.
The collection of standard charts of
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
is an atlas on the set
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
, and the transition maps between its charts are translations (§
A.1
, p. 49).
Proof.
The domains of the standard charts cover
 $\|{G}\|$
. Given two arrows
 $a$
and
 $a'$
with
 $a\not =a'$
, the domains of
 ${{\phi }}_a$
and
 ${{\phi }}_{{{a'}}}$
are disjoint. By applying the distributivity of
 $\cap$
over
 $\cup$
, and the fact that
 ${{I}}_{{{x}}}\cap {{J}}_{{{x}}}=\emptyset$
– see (2), the intersection of
 $\textit {dom}\:{{\phi }}_{{{ab}}}$
and
 $\textit {dom}\:{{\phi }}_{{{a'b'}}}$
is the disjoint union
 \begin{equation*} (\{a\}\cap \{a'\}) \times ({{J}}_{{{a}}}\cap {{J}}_{{{a'}}}) \:\: \cup \:\: \big (\{(a,b)\}\cap \{(a',b')\}\big ) \:\: \cup \:\: (\{b\}\cap \{b'\}) \times ({{I}}_{{{b}}}\cap {{I}}_{{{b'}}}). \end{equation*}
The transition map
 ${{\phi }}_{{{a'b'}}}\circ {{{{\phi }}_{{{ab}}}}}^{{-1}}$
is an identity whose domain is
 $\textit {cod}\,({{\phi }}_{{{ab}}})$
if
 $(a,b)=(a',b')$
, the interval
 ${{J}}_{{{a}}}$
if
 $a=a'$
and
 $b\not =b'$
, the interval
 ${{I}}_{{{b}}}$
if
 $a\not =a'$
and
 $b=b'$
, and empty otherwise. If
 $c\not \in \{a,b\}$
, then the domains of the charts
 ${{\phi }}_{{{ab}}}$
and
 ${{\phi }}_{{{c}}}$
are disjoint. So the only nontrivial case is when
 $c\in \{a,b\}$
. We take
 $\{a\} \times {{J}}_{{{a}}}$
as witness of compatibility of
 ${{\phi }}_{{{ab}}}$
and
 ${{\phi }}_{{{a}}}$
since we have
 \begin{equation*} {{\phi }}_{{{ab}}}\circ {{{{\phi }}_a}}^{{-1}}\quad :\quad t\:\in \:{{J}}_{{{a}}} \quad \mapsto \quad t-\ell (a)\:\in \:-{{I}}_{{{a}}}, \end{equation*}
and
 ${{J}}_{{{b}}}$
as witness of compatibility of
 ${{\phi }}_{{{ab}}}$
and
 ${{\phi }}_{{{b}}}$
since
 ${{\phi }}_{{{ab}}}\circ {{{{\phi }}_b}}^{{-1}}$
is just the identity map on
 ${{J}}_{{{b}}}$
. Hence the transition maps are translations. We readily deduce the higher dimensional case from the description of the transition maps between the charts of a product of atlases (Def. A.5); in particular, the transition maps are translations as products of such maps.
Definition 3.3.
The standard atlas of the tuple of graphs
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
is the collection of standard charts of
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
(Def. 3.1); following Def. A.5
, it is the product atlas
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
of the standard atlases
 $\mathcal{A}_{{G_i}}$
of
 ${{G}}_{{{i}}}$
.
Example 3.4.
The canonical bijection
 $\|{{{G}}_{{{\mathbb{Z}}}}}\|\cong {\mathbb{R}}$
(Ex. 2.20) induces a smooth diffeomorphism (Def. A.5) between the standard atlas of
 ${{G}}_{{{\mathbb{Z}}}}$
and
 $\{{id}_{{id}{{\mathbb{R}}}}\}$
(Ex. A.7).
Remark 3.5.
The topology of
 $\mathcal{A}_{{G}}$
(Def. A.8) is Hausdorff if, and only if, the graph
 $G$
has no singular traversal (Def. 2.14); in which case, it is the topology of
 $\|{G}\|$
(Rem. 2.18). If
 $G$
has a singular traversal, then the topology of
 $\mathcal{A}_{{G}}$
(which is
 ${{T}}_{{{1}}}$
by Lem. A.9) differs from that of
 $\|{G}\|$
(which is not
 ${{T}}_{{{1}}}$
by Rem. 2.18).
3.2 Tangent vectors
For any standard charts
 $\phi$
and
 $\psi$
of
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
, the derivative of
 $\psi \circ {{\phi }}^{{-1}}$
at any point of
 $\textit {cod}\,\phi \cap \textit {cod}\,\psi$
is the identity map
 ${id}_{{\mathbb{R}}^n}:{\mathbb{R}}^n\to {\mathbb{R}}^n$
(Lem. 3.2). It follows from §A.3 (24) that for all
 $v\in T_{p}(\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}})$
, the representation
 ${{[[{{v}}]]}}_{{{p}}}^{{{\phi }}}$
does not depend on the standard chart
 $\phi$
. So we may as well decide that the tangent space of
 $\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}}$
at
 $p$
is
 \begin{equation} T_{p}(\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}}) = \{p\} \times {\mathbb{R}}^n \end{equation}
with the obvious topological vector space structure.
Definition 3.6.
A standard tangent chart of
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
is a product
 $\phi \times {id}_{{\mathbb{R}}^n}$
with
 $\phi$
a standard chart of
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
; it corresponds to the chart
 $T\phi$
from §
A.3
(
25
) provided that following (
3
) we adopt
 $\|{{{G}}_{{{n}}}}\|\: \times \:{\mathbb{R}}^n$
as the underlying set of the tangent bundle
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
:
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
:
 \begin{equation*} \begin{array}{rclcl} T\phi &:&\textit {dom}\:\phi \times {\mathbb{R}}^n&\to &\textit {cod}\,\phi \times {\mathbb{R}}^n \\ & & (p,t) & \mapsto & (\phi p,t). \end{array} \end{equation*}
The standard tangent atlas of
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
is the collection of its standard tangent charts. The standard representation of the tangent bundle of
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
is the set
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|\: \times \:{\mathbb{R}}^n$
equipped with the standard tangent atlas. The standard parallelization of
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
is the tuple of vector fields
 $({{f}}_{,\ldots ,{{f}}_{1}}n)$
with
 \begin{equation*} \begin{array}{lcccr} {{f}}_i&:&\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|&\to &(\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|)\: \times \:{\mathbb{R}}^n \\ & & p&\mapsto &p,{{e}}_{{{i}}} \end{array} \end{equation*}
for
 $i\in \{{1},\ldots ,{n}\}$
and
 ${{e}}_{{{i}}}$
the
 $i^{th}$
vector of the canonical basis of
 ${\mathbb{R}}^n$
. The standard basis of the tangent space at
 $p$
is
 $({f}_{p}(){n}\ldots {n}{f}_{{1}}(),)$
; its positive cone is the set of vectors whose coordinates in the standard basis are non-negative.
Remark 3.7.
Strictly speaking, even if
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
and
 $({{g}}_{{1},\ldots ,{{g}}_{m}})$
are standard parallelizations (Def. 3.6), the tuple of vector fields
 $({{f}}_{{1},\ldots ,{{f}}_{n}},{{g}}_{{1},\ldots ,{{g}}_{m}})$
is not. Yet, the latter is related to a standard parallelization by the obvious smooth diffeomorphism (Def. A.5)
 \begin{equation*} (\mathcal{A}_{{G_{1}}} \times {\mathbb{R}}) \times \cdots \times (\mathcal{A}_{{G_{n}}} \times {\mathbb{R}}){} \quad \cong \quad (\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}})\: \times \:{\mathbb{R}}^n. \end{equation*}
3.3 Derivatives
Let
 $f:\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}\to \mathcal{A}_{{G'_{1}}} \times \cdots \times \mathcal{A}_{{G'_{m}}}$
be a smooth map (Def. A.5) between standard atlases (Def. 3.3). The transition maps between standard charts are translations (Lem. 3.2) so we have
 ${D{({{\phi }}_{{{0}}}\circ {{{{\phi }}_{{{1}}}}}^{{-1}})}}_{{\phi _1(p)}}={id}_{{\mathbb{R}}^n}$
and
 ${D{({{\psi }}_{{{1}}}\circ {{\psi }_{{0}}^{{-1}}})}}_{{{{\psi }}_0(f{p})}}={id}_{{\mathbb{R}}^m}$
for all
 ${{\phi }}_0$
,
 ${{\phi }}_{{{1}}}\in \mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
and
 ${{\psi }}_0$
,
 ${{\psi }}_{{{1}}}\in \mathcal{A}_{{G'_{1}}} \times \cdots \times \mathcal{A}_{{G'_{m}}}$
, with
 $p\in \textit {dom}\:({{\phi }}_{{{0}}})\cap \textit {dom}\:({{\phi }}_{{{1}}})$
— see §A.1, p. 49. From Lem. A.6, we deduce that the representation of
 ${D{f}}_{{p}}$
(Def. A.14) does not depend on the standard charts in which it is represented, so it can be identified with an
 $n \times m$
matrix with entries in
 $\mathbb{R}$
which we just denote by
 $f'p$
without mentioning any chart:
Definition 3.8.
The matrix
 $f'p$
is called the standard representation of
 ${D{f}}_{{p}}$
and we have
 \begin{equation*} {D{f}}_{{p}}(p,t) = Tf(p,t) = \big (\:fp,\:f'p\cdot t\:\big ) \end{equation*}
with
 $f'p\cdot t$
being the product of the standard representation of
 ${D{f}}_{{p}}$
and the vector
 $t\in {\mathbb{R}}^n$
.
Remark 3.9.
The standard representation
 $f'p$
(Def. 3.8) is the matrix of the linear map
 ${D{f}}_{{p}}$
in the standard bases (Def. 3.6) of the tangent spaces at
 $p$
and
 $fp$
.
Remark 3.10.
If
 $\gamma$
is a curve on the standard atlas
 $\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}}$
, then for every standard chart
 $\phi$
whose domain contains
 $\gamma ({{t}}_{{{0}}})$
, we have the curve
 $\phi \circ \gamma$
in
 ${\mathbb{R}}^n$
. By Rem. 3.9
, the coordinates of the “speed” vector
 $(\phi \circ \gamma )'({{t}}_{{{0}}})$
in the canonical basis of
 ${\mathbb{R}}^n$
are the coordinates of the tangent vector
 $\gamma '({{t}}_{{{0}}})$
in the standard basis at
 $\gamma ({{t}}_{{{0}}})$
.
3.4 Functoriality
We denote by
 $\mathbf{Grph}_\ell$
the category whose objects are graphs equipped with a map
 $\ell :{{G}}^{{({1})}}\to ]{{0}},{{\infty }}[$
such that
 $\inf (\ell )\not =0$
, and whose morphisms are
 $2$
-tuples
 $(g,{{r}}_{{r}{{g}}})$
with
 $g:G\to G'$
a graph morphism such that
 $\ell '({{g}}_{{{1}}}(a))={{r}}_{{r}{{g}}}\cdot \ell (a)$
for every arrow
 $a$
. We would like to extend the construction
 $G\mapsto \mathcal{A}_{{G}}$
(Def. 3.3) to a functor
 $ \mathcal{A}_{{\ast }}:\mathbf{Grph}_\ell \to \mathbf{Atl}$
. To every morphism
 $(g,{{r}}_{{r}{{g}}})$
of
 $\mathbf{Grph}_\ell$
, we associate the map
 $f:\|{G}\|\to \|{G'}\|$
defined by
 $f(a,t)=({{g}}_{{{1}}}a,{{r}}_{{r}{{g}}}t)$
for every arrow
 $a$
of
 $G$
and
 $t\in \:]{{0}},{{\ell (a)}}[$
, and by
 $f(a,b)=({{g}}_{{{1}}}a,{{g}}_{{{1}}}b)$
for every traversal
 $(a,b)$
of
 $G$
. Such a map
 $f$
is called a dilation. Denoting by
 ${{\psi }}_{{{a'}}}$
and
 ${{\psi }}_{{{a'b'}}}$
the charts of the standard atlas of
 $\mathcal{A}_{{G'}}$
associated with
 $a'={{g}}_{{{1}}}a$
and
 $(a',b')=f(a,b)=({{g}}_{{{1}}}a,{{g}}_{{{1}}}b)$
, we have
 \begin{equation*} \begin{array}{lcrclcrcl} {{\psi }}_{{{a'}}}\circ f\circ {{{{\phi }}_{{{a}}}}}^{{-1}} & \quad :\quad \ & t & \in & ]{{0}},{{\ell (a)}}[ & \quad \mapsto \quad \ & {{r}}_{{r}{{g}}}t & \in & ]{{0}},{{\ell (a')}}[\\ {{\psi }}_{{{a'b'}}}\circ f\circ {{{{\phi }}_{{{ab}}}}}^{{-1}} & : & t & \in & ]{{\tfrac {-\ell (a)}2}},{{\tfrac {\ell (b)}2}}[ & \mapsto & {{r}}_{{r}{{g}}}t & \in & ]{{\tfrac {-\ell (a')}2}},{{\tfrac {\ell (b')}2}}[ \end{array} \end{equation*}
so the map
 $f$
is smooth, and with the notation from Def. 3.8 we have
 $f'p={{r}}_{{r}{{g}}}\in {\mathbb{R}}$
for all
 $p\in \|{G}\|$
.
4. Metrics On Standard Atlases
Given a map
 $\ell :{{G}}^{{({1})}}\to \mathbb{R}_{{+}}$
assigning a length to every arrow of a graph
 $G$
, there is a pseudometric
 ${{d}}_{{{|{G}|}}}$
on the set
 $|{G}|$
(Def. 4.5) in which every arrow
 $a$
induces a path of length
 $\ell (a)$
, and the distance between two points is the greatest lower bound of the lengths of the paths joining them. Such a space is called a metric graph (Def. 4.13), and it can be defined as the quotient of a disjoint union of intervals (Bridson and Haefliger Reference Bridson and Haefliger1999, 5.21(3)). If
 $\inf (\ell )\not =0$
, then the pseudometric
 ${{d}}_{{{|{G}|}}}$
is an intrinsic metric (Bridson and Haefliger Reference Bridson and Haefliger1999, 5.20, 5.28); this is what motivates the constraint imposed on the objects of
 $\mathbf{Grph}_\ell$
. The elementary construction given here is standard; we have slightly adapted the presentation of (Bridson and Haefliger Reference Bridson and Haefliger1999, §1.9, p. 6) to our needs.
The pseudometric
 ${{d}}_{{{\|{G}\|}}}$
on the set
 $\|{G}\|$
is the (only) one that makes the blowup map
 ${\beta }_G$
an isometry (Def. 4.14). For
 $\alpha \in [{{1}},{{\infty }}]$
, the
 $\alpha$
-standard pseudometric on
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
(Def. 4.17) and the standard parallelization on
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
(together with the
 $\alpha$
-norm on
 ${\mathbb{R}}^n$
) induce two natural definition of the length of a piecewise smooth path (Def. 4.18 and 4.22); they coincide (Lem. 4.24) and determine the pseudometrics on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
and
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
(Lem. 4.20 and Thm. 4.26).
Let
 $G$
be a graph together with a map
 $\ell :{{G}}^{{({1})}}\to [{{R}},{{\infty }}[$
with
 $R\gt 0$
. Each arrow
 $a$
comes with the canonical map (see Def. 2.6 for
 $|{G}|$
)
 \begin{equation} {{\chi }}_a\::\:t\in [{{0}},{{\ell (a)}}]\:\mapsto \: \left \{ \begin{array}{ll} \textrm {src}\ a & \text{if}\ t=0\\[1.2mm] \textrm {tgt}\; a & \text{if}\ t=\ell (a)\\[1.2mm] (a,t) & \text{otherwise} \end{array} \right .\in \:|{G}|\:. \end{equation}
Remark 4.1.
The finest topology making all the maps
 ${{\chi }}_a$
continuous is that of
 $|{G}|$
(Def. 2.10). Indeed, if
 $V$
is an open set of the latter topology containing the vertex
 $v$
, and if
 $a$
is an arrow of
 $G$
such that
 $\textrm {src}(a)=v$
(resp.
 $\textrm {tgt}(a)=v$
), then
 ${{{{\chi }}_a}}^{{-1}}(V)$
contains
 $[{{0}},{{\varepsilon }}[$
(resp.
 $]{{\ell (a)-\varepsilon }},{{\ell (a)}}]$
).
Remark 4.2.
Given an arrow
 $a$
and a traversal
 $(a,b)$
of
 $G$
(Def. 2.14), the standard charts
 ${{\phi }}_a$
and
 ${{\phi }}_{{{ab}}}$
(Def. 3.1) are related to the mappings
 ${{\chi }}_a$
and
 ${{\chi }}_b$
: for every
 $t\in \textit {cod}\,{{\phi }}_a$
, we have
 ${\beta }_G\circ {{{{\phi }}_a}}^{{-1}}(t)={{\chi }}_a(t)=(a,t)$
, and for every
 $t\in \textit {cod}\,{{\phi }}_{{{ab}}}$
, we have
 \begin{equation*} {\beta }_G\circ {{{{\phi }}_{{{ab}}}}}^{{-1}}(t) = \left \{ \begin{array}{ll} {{\chi }}_a(\ell (a)+t)=(a,\ell (a)+t) & \text{ if } t\lt 0 \\[1.2mm] {{\chi }}_a(\ell (a))=\textrm {tgt}\; a=\textrm {src}\; b={{\chi }}_b(0) & \text{ if } t=0 \\[1.2mm] {{\chi }}_b(t)=(b,t) & \text{ if } t\gt 0 \end{array} \right . \end{equation*}
with
 ${\beta }_G$
denoting the blowup of
 $G$
(Def. 2.15).
A path
 $\gamma$
on a topological space
 $X$
(p. 7) is said to be an arc (resp. a pseudo-arc) when
 ${{\gamma }}^{{-1}}\{p\}$
contains at most one element (resp. when
 ${{\gamma }}^{{-1}}\{p\}$
is connected) for every
 $p\in X$
.
Definition 4.3.
A step
 $s$
is a path of the form
 ${{\chi }}_a\circ \theta$
with
 $\theta$
an arc on
 $[{{0}},{{\ell (a)}}]$
; it is said to be affine when so is
 $\theta$
; directed or antidirected according to whether
 $\theta$
is increasing or decreasing; standard if
 $\theta$
is an inclusion
 $[{{x}},{{y}}]\hookrightarrow [{{0}},{{\ell (a)}}]$
or its opposite, in which case the step
 $s$
is denoted by
 $(a,x,y)$
or
 $(a,y,x)$
accordingly. We define the length of
 $s$
, denoted by
 $\ell (s)$
, as the length of the interval
 $\textit {img}\:\theta$
. The support of
 $s$
is the arrow
 $a$
. The steps
 ${{\chi }}_a\circ \theta$
and
 ${{\chi }}_b\circ \theta '$
are said to be overlapping when
 $a=b$
and the interior of
 $\textit {img}\:\theta \cap \textit {img}\:\theta '$
is nonempty. In higher dimensions, a step of
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
is a product
 ${{s}}_{1}{ \times }\cdots { \times }{{s}}_{n}$
of steps
 ${{s}}_{{{i}}}$
of
 $|{{{G}}_{{{i}}}}|$
.
Definition 4.4.
A path
 $\gamma$
on
 $|{G}|$
is said to be admissible (resp. piecewise affine) when it can be written as a (finite) concatenation of steps (resp. affine steps)
 ${{s}}_{{1},\ldots ,{{s}}_{n}}$
(Def. 4.3); the length of
 $\gamma$
is
 $\ell (\gamma )={\ell }(_{s}){n}\cdots {n}{\ell }(_{1})+$
(this sum does not depend on
 ${{s}}_{{1},\ldots ,{{s}}_{n}}$
—see Lem. B.17). A path on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
is said to be admissible (resp. piecewise affine) when so are all its components. A path on
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
is said to be piecewise affine when so is its image under the product of blowups
 ${{\beta }}_{1}{ \times }\cdots { \times }{{\beta }}_{n}$
(Def. 2.15).
A weak reparametrization is a non-decreasing path onto an interval (i.e. a non-decreasing surjection between two intervals). A reparametrization is an increasing path onto an interval (i.e. an increasing surjection between two intervals). The class of admissible paths is stable under reparametrization; the image and the length of an admissible path are left unchanged under reparametrization, every step is admissible and for every arrow
 $a$
, we have
 $\ell (a)=\ell ({{\chi }}_a)$
, see (4).
Definition 4.5.
The standard pseudometric (one readily checks that it is a pseudometric) on
 $|{G}|$
(Def. 2.6) is the map
 ${{d}}_{{{|{G}|}}}\::\:|{G}| \times |{G}|\to \mathbb{R}_{{+}}\cup \{\infty \}$
defined by
 \begin{equation*} {{d}}_{{{|{G}|}}}(p,q) = \inf \big \{\:\ell (\gamma )\:\ \big |\ \:\gamma \text{ : admissible path from } p \text{ to } q\:\big \} \end{equation*}
with the convention that
 $\inf \emptyset =\infty$
;
 $p$
and
 $q$
are said to be neighbors when
 ${{d}}_{{{|{G}|}}}(p,q)\lt \tfrac R2$
.
Remark 4.6.
Let
 $\gamma$
be an admissible path from
 $p$
to
 $q$
. The topology of
 $|{G}|$
(Def. 2.10) is Hausdorff (Rem. 2.9) so we have an arc
 $\alpha$
from
 $p$
to
 $q$
such that
 $\textit {img}\:(\alpha )\subseteq \textit {img}\:(\gamma )$
(Lem. B.2). By Lem. B.18 and B.19
, we have
 $\ell (\alpha )\leqslant \ell (\gamma )$
, so we can write “arc” instead of “admissible path” in Def. 4.5
.
In the (discrete) context of a graph, one usually says that two vertices are neighbors when they are the extremities of an arrow; the idea is that an arrow is a geodesic between two vertices. On the contrary, no two vertices of
 $G$
are neighbors in the sense of Def. 4.5 because the length of any admissible path joining them is at least
 $R$
. The description of the unique geodesic joining two neighbors (Lem. 4.10) requires some extra notions, which we now introduce.
Let
 $p={{\chi }}_a(s)$
and
 $q={{\chi }}_a(t)$
with
 $\{s,t\}\not \subseteq \{0,\ell (a)\}$
, which amounts to say that at least one of the points
 $p$
and
 $q$
is not a vertex.
-
i) If
$\{s,t\}\subseteq \:]{{0}},{{\ell (a)}}[$
or
$\textrm {src}\ a\not =\textrm {tgt}\; a$
, then
$(a,s,t)$
is the unique standard step from
$p$
to
$q$
(Def. 4.3), -
ii) If
$\{s,t\}\not \subseteq \:]{{0}},{{\ell (a)}}[$
and
$\textrm {src}\ a=\textrm {tgt}\; a$
, then we have exactly two standard steps
$\sigma$
and
$\sigma '$
from
$p$
to
$q$
, namely:


In both cases, the sum of their lengths is
 $\ell (a)$
, and only one of them is directed. From the extra assumption that
 $\tfrac {\ell (a)}2\not \in \{s,t\}$
(i.e. neither
 $p$
nor
 $q$
stands on the midpoint of
 $\{a\} \times ]{{0}},{{a}}[$
), we deduce that one of the steps
 $\sigma$
and
 $\sigma '$
is strictly shorter than the other.
Definition 4.7.
Let
 $p$
,
 $q\in \textit {img}\:({{\chi }}_a)$
, one of them not being a vertex. The dash from
 $p$
to
 $q$
, denoted by
 $p\to q$
, is the shortest standard step from
 $p$
to
 $q$
(Def. 4.3) with the convention that if there are two such steps, then
 $p\to q$
is the directed one. When it is not the only step from
 $p$
to
 $q$
, the other one is called the complement of
 $p\to q$
. In higher dimensions, for
 $p=({{p}}_{{1},\ldots ,{{p}}_{n}})$
and
 $q=({{q}}_{{1},\ldots ,{{q}}_{n}})$
in
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
, if the dash
 ${{p}}_{{{k}}}\to {{q}}_{{{k}}}$
exists for every
 $k\in \{{1},\ldots ,{n}\}$
, then we write
 $p\to q$
to denote the product
 $({{p}}_{{{1}}}\to {{q}}_{{{1}}}) \times \cdots \times ({{p}}_{{{n}}}\to {{q}}_{{{n}}})$
.
Remark 4.8.
Let
 $\gamma$
be an admissible path (Def. 4.4) from
 $(a,t)$
to some vertex. By a connectedness argument, we have
 ${{\chi }}_a[{{0}},{{t}}]\subseteq \textit {img}\:(\gamma )$
or
 ${{\chi }}_a[{{t}},{{\ell (a)}}]\subseteq \textit {img}\:(\gamma )$
. In particular, the restrictions of
 ${{\chi }}_a$
to
 $[{{0}},{{t}}]$
and
 $[{{t}},{{\ell (a)}}]$
are arcs (Lem. B.14). It follows from Lem. B.19 that
 $\ell (\gamma )\geqslant \min \{t,\ell (a)-t\}$
. If
 $\gamma$
visits two distinct vertices, then by a connectedness argument, we have
 $\textit {img}\:({{\chi }}_a)\subseteq \textit {img}\:(\gamma )$
for some arrow
 $a$
, so
 $\ell (\gamma )\geqslant \ell (a)\geqslant R$
.
Remark 4.9.
The step
 ${{\chi }}_a\circ \theta$
is an arc if, and only if,
 $\textrm {src}(a)\not =\textrm {tgt}(a)$
or
 $\textit {img}\:\theta \not =\textit {dom}\:({{\chi }}_a)$
. It follows that every dash is an arc.
Lemma 4.10.
Suppose that
 $p={{\chi }}_a(s)$
and
 $q={{\chi }}_b(t)$
with
 ${{d}}_{{{|{G}|}}}(p,q)\lt \tfrac R2$
and
 $p\not =q$
.
-
1) If
$a=b$
and (
$\textrm {src}\ a\not =\textrm {tgt}\; a$
or
$|t-s|\lt \tfrac 12\ell (a)$
), then
$\ell (p\to q)={{d}}_{{{|{G}|}}}(p,q)=|t-s|$
. -
2) If
$a=b$
and
$\textrm {src}\ a=\textrm {tgt}\; a$
and
$|t-s|\geqslant \tfrac 12\ell (a)$
, or if
$a\not =b$
, then there is a unique vertex
$v$
(which is an endpoint shared by
$a$
and
$b$
) such that
$\ell (p\to v\to q)={{d}}_{{{|{G}|}}}(p,q)$
, that is,
$\ell (a)-|t-s|$
in the case where
$a=b$
.


Moreover, the only admissible path of length
 ${{d}}_{{{|{G}|}}}(p,q)$
from
 $p$
to
 $q$
is, up to reparametrization (p. 4), the arc
 $p\to q$
or the arc
 $p\to v\to q$
accordingly.
Proof.
The arrows
 $a$
and
 $b$
share at least one endpoint, and one (at least) of the points
 $p$
and
 $q$
is not a vertex (Rem. 4.8). We have an admissible path
 $\gamma$
from
 $p$
to
 $q$
with
 $\ell (\gamma )\lt R/2$
because
 ${{d}}_{{{|{G}|}}}(p,q)\lt R/2$
(Def. 4.5). There are three cases to examine:
Case 1. Assume that
 $a\not =b$
.
By Rem. 4.8 and because
 $\ell (\gamma )\lt R/2$
, we have
 $\textit {img}\:(p\to v)\subseteq \textit {img}\:(\gamma )$
for some
 $v\in \{\textrm {src}\ a,\textrm {tgt}\; a\}$
(Def. 4.7). Similarly, we have
 $\textit {img}\:(v'\to q)\subseteq \textit {img}\:(\gamma )$
for some
 $v'\in \{\textrm {src}\; b,\textrm {tgt}\ b\}$
. We deduce that
 $v=v'$
from Rem. 4.8. The admissible path
 $\alpha =(p\to v\to q)$
is an arc because so are the dashes
 $p\to v$
and
 $v\to q$
(Rem. 4.9) and
 $\textit {img}\:(p\to v)\cap \textit {img}\:(v\to q)=\{v\}$
. We apply Lem. B.19 to conclude that
 $\ell (\alpha )\leqslant \ell (\gamma )$
with equality if, and only if,
 $\gamma$
is an arc having the same image as
 $\alpha$
, in which case,
 $\gamma$
and
 $\alpha$
are equal up to reparametrization (Rem. B.1). By Def. 4.5, we have
 $\ell (\alpha )= {{d}}_{{{|{G}|}}}(p,q)$
.
The two remaining cases share the assumption that
 $a=b$
. Up to exchanging the roles of
 $s$
and
 $t$
, we can suppose that
 $s\leqslant t$
. By Rem. 4.8, the image of
 $\gamma$
either contains the set
 $B=\{a\} \times [{{s}},{{t}}]$
or the set
 $C=\{a\} \times ([{{0}},{{s}}]\cup [{{t}},{{\ell (a)}}])$
.
Case 2. Assume that
 $\textrm {src}\ a=\textrm {tgt}\; a=v$
, and
 $t-s\geqslant \tfrac 12\ell (a)$
.
The standard steps
 $(a,s,0)$
and
 $(a,\ell (a),t)$
are
 $p\to v$
and
 $v\to q$
(Def. 4.7). The path
 $\gamma$
does not cover
 $B$
, otherwise we would have
 $\ell (\gamma )\geqslant R/2$
(Lem. B.19). Therefore,
 $\textit {img}\:(\gamma )$
contains
 $C$
, which is the image of
 $p\to v\to q$
. We have
 $\textit {img}\:(p\to v)\cap \textit {img}\:(v\to q)=\{v\}$
, from which we deduce, as in the first case, that
 $\ell (p\to v\to q)\leqslant \ell (\gamma )$
with equality if, and only if,
 $\gamma$
and
 $p\to v\to q$
are equal up to reparametrization.
Case 3. Assume that
 $\textrm {src}\ a\not =\textrm {tgt}\; a$
or
 $t-s\lt \tfrac 12\ell (a)$
.
The dash
 $p\to q$
is well-defined (Def. 4.7), and its length is
 $t-s$
. If
 $C\subseteq \textit {img}\:(\gamma )$
then one of the following situations occurs:
-
–
$\gamma$
visits
$\textrm {src}\ a$
and
$\textrm {tgt}\; a$
(which are distinct), so
$\ell (\gamma )\gt R$
(Rem. 4.8), or -
–
$\ell (\gamma )\geqslant \ell (a)-(t-s)\gt \tfrac 12\ell (a)$
(Lem. B.19).


In both situations, the inequality
 $\ell (\gamma )\lt R/2$
is not satisfied; therefore,
 $\textit {img}\:(\gamma )$
contains
 $B$
, which is the trace of the arc
 $p\to q$
(Rem. 4.9). With the same arguments as in the two first cases, we deduce that
 $\ell (p\to q)\leqslant \ell (\gamma )$
with equality if, and only if,
 $\gamma$
and
 $p\to q$
are equal up to reparametrization.
Remark 4.11.
As an immediate consequence of Lem. 4.10
, the pseudometric
 ${{d}}_{{{|{G}|}}}$
is a metric.
Lemma 4.12.
The metric
 ${{d}}_{{{|{G}|}}}$
is intrinsic (Def. B.10).
Proof.
Given
 $p$
,
 $q\in |{G}|$
, we have
 \begin{equation*} \begin{array}{lcll} {{d}}_{{{|{G}|}}}(p,q) & = & \inf \big \{\:\ell (\gamma )\:\ \big |\ \:\gamma \text{ : admissible path from } p \text{ to } q \:\big \} & \quad \text{(Def. {4.5})}\\[1mm] & = & \inf \big \{\:\ell (\gamma )\:\ \big |\ \:\gamma \text{ : arc from $p$ to $q$}\:\big \} & \quad \text{(Rem. {4.6})}\\[1mm] & = & \inf \big \{\:L(\gamma )\:\ \big |\ \:\gamma \text{ : arc from $p$ to $q$}\:\big \} & \quad \text{(Lem. {B.18} and {B.20})}\\[1mm] & = & \inf \big \{\:L(\gamma )\:\ \big |\ \:\gamma \text{ : path from $p$ to $q$}\:\big \} & \quad \text{(Lem. {B.21}).} \end{array} \end{equation*}
If we allow the lengths of arrows to be taken in
 $\mathbb{R}_{{+}}$
(or even
 $]{{0}},{{\infty }}[$
) instead of
 $[{{R}},{{\infty }}[$
, then there might be arbitrarily short paths joining two distinct points, resulting in a pseudometric space instead of a metric one.
Definition 4.13.
The metric graph associated with
 $G$
is the metric space
 $(|{G}|,{{d}}_{{{|{G}|}}})$
.
We lift the distance
 ${{d}}_{{{|{G}|}}}$
along the blowup
 ${\beta }_G$
(Def. 2.15):
Definition 4.14.
The standard pseudometric on
 $\|{G}\|$
is
 ${{d}}_{{{|{G}|}}}\circ ({\beta }_G \times {\beta }_G)$
, we denote it by
 ${{d}}_{{{\|{G}\|}}}$
.
Remark 4.15.
A map
 $f$
from a topological space
 $X$
to
 $\|{G}\|$
(equipped with the pseudometric topology) is continuous if, and only if, so is the composite
 ${\beta }_G\circ f$
. Suppose that
 ${\beta }_G\circ f$
is continuous at
 ${{x}}_{{{0}}}\in X$
, and let
 $\varepsilon \gt 0$
. We have a neighborhood
 $V$
of
 ${{x}}_{{{0}}}$
such that
 ${\beta }_G(f(V))\subseteq B({\beta }_G(f({{x}}_{{{0}}})),\varepsilon )$
. Given
 $x\in V$
, we have
 ${{d}}_{{{\|{G}\|}}}(f({{x}}_{{{0}}}),f(x))={{d}}_{{{|{G}|}}}({\beta }_G(f({{x}}_{{{0}}})),{\beta }_G(f(x)))$
(Def. 4.14); therefore,
 $f(V)\subseteq B(f({{x}}_{{{0}}}),\varepsilon )$
, and
 $f$
is continuous. The converse is immediate. In particular, every path on
 $\textit {img}\:({\beta }_G)$
can be lifted to a path on
 $(\|{G}\|,{{d}}_{{{\|{G}\|}}})$
of the same length. Moreover, every arc on
 $(|{G}|,{{d}}_{{{|{G}|}}})$
whose extremities belong to
 $\textit {img}\:({\beta }_G)$
is included in
 $\textit {img}\:({\beta }_G)$
: indeed, if an arc on
 $(|{G}|,{{d}}_{{{|{G}|}}})$
visits an endpoint
 $p$
of
 $G$
(i.e., to say
 $p\not \in \textit {img}\:({{\beta }}_{{{|{G}|}}})$
by Rem. 2.16), then
 $p$
is an extremity of this arc. We conclude from Rem. 4.6 and Lem. 4.12 that
 ${{d}}_{{{\|{G}\|}}}$
is intrinsic (Def. B.10).
Remark 4.16.
By Def. 4.14
, the inverse image of an open ball of
 $(|{G}|,{{d}}_{{{|{G}|}}})$
under
 ${\beta }_G$
is an open ball of
 $(\|{G}\|,{{d}}_{{{\|{G}\|}}})$
. From the description of the small open balls of
 $(|{G}|,{{d}}_{{{|{G}|}}})$
given in Prop. B.22
, and the fact that
 ${{{\beta }_G}}^{{-1}}(\{a\} \times ]{{t-r}},{{t+r}}[)=\{a\} \times ]{{t-r}},{{t+r}}[$
and
 ${{{\beta }_G}}^{{-1}}\big (S(v,r)\big )=(S(v,r)\setminus \{v\})\cup {{{\beta }_G}}^{{-1}}(\{v\})$
, we deduce that the topology of the standard atlas
 $\mathcal{A}_{{G}}$
(Def. 3.3 and A.8) is finer than the topology of the standard pseudometric on
 $\|{G}\|$
; it is in fact strictly finer if, and only if,
 $G$
has a singular traversal (Def. 2.14), which is the case for most of the graphs we are interested in.
For the rest of §4, we fix
 $\alpha \in [{{1}},{{\infty }}]$
and a tuple of graphs
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
.
Definition 4.17.
The standard
 $\alpha$
-distance on
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
refers to both the
 $\alpha$
-product
 ${{d}}^{{({\alpha })}}$
of the standard metrics
 ${{d}}_{{{|{G_i}|}}}$
(Def. 4.5), and to the
 $\alpha$
-product
 ${\,{\tilde{\!d}}}^{{({\alpha })}}$
of the standard pseudometrics
 ${{d}}_{{{\|{G_i}\|}}}$
(Def. 4.14), with the notion of
 $\alpha$
-product given in Def. B.11
.
A subdivision of the interval
 $[{{a}},{{b}}]\subseteq {\mathbb{R}}$
(with
 $a\leqslant b$
) is a finite increasing sequence of elements of
 $[{{a}},{{b}}]$
whose first and last elements are
 $a$
and
 $b$
.
Definition 4.18 (Special instance of Def. B.5). The
 $\alpha$
-length of a path
 $\gamma$
on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
(resp.
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
), which we denote by
 $L^{\alpha }(\gamma )$
, is the least upper bound of the sums
 $\sum _{i=1}^k{{d}}^{{({\alpha })}}\big (\gamma ({{t}}_{{{i-1}}}),\gamma ({{t}}_{{{i}}})\big )$
for
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}$
subdivisions of
 $\textit {dom}\:\gamma$
.
Remark 4.19.
Every path
 $\gamma$
on
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
is continuous with respect to the pseudometric from Def. 4.14
, which is equivalent to having
 ${{\beta }}_{{{G_i}}}\circ {{\gamma }}_i$
continuous on the metric graph
 $|{{{G}}_{{{i}}}}|$
for every
 $i\in \{{1},\ldots ,{n}\}$
(Rem. 4.15), and we have
 $L^{\alpha }(\gamma )=L^{\alpha }(({{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}})\circ \gamma )$
.
Lemma 4.20.
The
 $\alpha$
-products
 ${{d}}^{{({\alpha })}}$
and
 ${\,{\tilde{\!d}}}^{{({\alpha })}}$
(Def. 4.17) are intrinsic (Def. B.10).
Each standard chart induces a “local isometry,” the codomain being understood as a subspace of
 ${\mathbb{R}}^n$
equipped with the
 $\alpha$
-norm (Def. B.11):
Proposition 4.21.
For every standard chart
 $\phi$
of
 ${{G}}_{1}{ \times }\cdots { \times }{{G}}_{n}$
(Def. 3.1) and all
 $p$
,
 $q\in \textit {dom}\:\phi$
, if
 ${{|\phi (p)-\phi (q)|}}_{{{\alpha }}}\lt \tfrac R2$
, then
 ${\,{\tilde{\!d}}}^{{({\alpha })}}(p,q)={{|\phi (p)-\phi (q)|}}_{{{\alpha }}}$
.
Proof.
We deal with the one-dimensional case first, so we have
 $\phi ={{\phi }}_a$
with
 $a$
arrow of
 $G$
, or
 $\phi ={{\phi }}_{{{ab}}}$
with
 $(a,b)$
traversal of
 $G$
. Let
 $\tilde p={\beta }_G(p)$
and
 $\tilde q={\beta }_G(q)$
. As a consequence of Rem. 4.2, we have one of the following situations (omitting those obtained by swapping the roles of
 $p$
and
 $q$
):
-
1)
$(a,{{\phi }}_a(p),{{\phi }}_a(q))$
is a standard step (Def. 4.3) from
$\tilde p={{\chi }}_a({{\phi }}_a(p))$
to
$\tilde q={{\chi }}_a({{\phi }}_a(q))$
. -
2)
$(b,{{\phi }}_{{{ab}}}(p),{{\phi }}_{{{ab}}}(q))$
is a standard step from
$\tilde p={{\chi }}_b({{\phi }}_{{{ab}}}(p))$
to
$\tilde q={{\chi }}_b({{\phi }}_{{{ab}}}(q))$
. -
3)
$(a,\ell (a)+{{\phi }}_{{{ab}}}(p),\ell (a)+{{\phi }}_{{{ab}}}(q))$
is a standard step from
$\tilde p={{\chi }}_a(\ell (a)+{{\phi }}_{{{ab}}}(p))$
to
$\tilde q={{\chi }}_a(\ell (a)+{{\phi }}_{{{ab}}}(q))$
. -
4)
$(a,\ell (a)+{{\phi }}_{{{ab}}}(p),\ell (a)),\:(b,0,{{\phi }}_{{{ab}}}(q))$
is an admissible path from
$\tilde p={{\chi }}_a(\ell (a)+{{\phi }}_{{{ab}}}(p))$
to
$\tilde q={{\chi }}_b({{\phi }}_{{{ab}}}(q))$
made of two standard steps.


The paths from
 $\tilde p$
to
 $\tilde q$
described above are of length
 $|\phi (p)-\phi (q)|\lt \tfrac R2$
, so
 ${{d}}_{{{|{G}|}}}(\tilde p,\tilde q)\lt \tfrac R2$
(Def. 4.5) and the steps appearing in them are dashes (Def. 4.7). In particular, Lem. 4.10 applies (because
 ${{d}}_{{{|{G}|}}}(p,q)\lt \tfrac R2$
) and each of these paths is the geodesic from
 $\tilde p$
to
 $\tilde q$
(according to the case under consideration), therefore,
 ${{d}}_{{{|{G}|}}}(\tilde p,\tilde q)=|\phi (p)-\phi (q)|$
. Since
 ${{d}}_{{{\|{G}\|}}}(p,q)={{d}}_{{{|{G}|}}}(\tilde p,\tilde q)$
(Def. 4.14), we have
 ${{d}}_{{{\|{G}\|}}}(p,q)=|\phi (p)-\phi (q)|$
. The higher dimension case immediately follows from Def. 4.17.
Definition 4.22 (Special instance of Def. B.13). Let
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
be the standard parallelization of
 $\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}}$
(Def. 3.6). The smoothed
 $\alpha$
-length of a smooth path
 $\gamma :[{{x}},{{y}}]\to \mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}}$
is given by
 \begin{equation*} {\mathcal L}^{{\alpha }}(\gamma ) = \int _{x}^{y} {{|\gamma '(t)|}}_{{{\alpha }}}\: dt \end{equation*}
with
 ${{|\gamma '(t)|}}_{{{\alpha }}}=({|{{a}}_{{{1}}}|}^\alpha +\cdots +{|{{a}}_{{{n}}}|}^\alpha )^{\tfrac 1\alpha }$
and
 $\gamma '(t)={{a}}_{{{1}}}{{f}}_{{{1}}}(\gamma (t))+\cdots +{{a}}_{{{n}}}{{f}}_{{{n}}}(\gamma (t))$
. The length of a piecewise smooth path
 ${{\gamma }}_{k}\cdots {k}{{\gamma }}_{1}{}$
is
 ${{\mathcal L}^{{\alpha }}}({{\gamma }}_{1}){+}\cdots {+}{{\mathcal L}^{{\alpha }}}({{\gamma }}_{k})$
. We just write
 $\mathcal L$
when
 $\alpha =1$
. The distance between points
 $p$
and
 $q$
is
 $ {{d}}_{{{\mathcal{A}_{{}}}}}^{{d}{({\alpha })}}(p,q) = \inf \{{\mathcal L}^{{\alpha }}(\gamma )\mid \}{\gamma \text{(piecewise) smooth path from}\ p \text{ to } q}$
.
Example 4.23.
Let
 $G$
be a graph with
 $(a,b)$
and
 $(c,d)$
two traversals at
 $v$
with
 $a$
,
 $b$
,
 $c$
, and
 $d$
pairwise distinct. There is a piecewise smooth path on the standard atlas
 $\mathcal{A}_{{G}}$
from
 $(a,b)$
to
 $(c,d)$
of arbitrarily small length. It suffices to consider the path
 $ (a,b)\:\to \:(a,1-\varepsilon )\:\to \:(a,d)\:\to \:(d,\varepsilon )\:\to \:(c,d)$
on Fig.
4
with
 $\varepsilon \gt 0$
arbitrarily small. In particular,
 $d((a,b),(c,d))=0$
and the greatest lower bound defining the distance between
 $(a,b)$
and
 $(c,d)$
is not reached.
Illustration of Ex. 4.23.

Lemma 4.24.
For every smooth path
 $\gamma$
on
 $\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}}$
, we have
 ${\mathcal L}^{{\alpha }}\gamma =L^{\alpha }\gamma$
.
Proof.
First observe that
 $\gamma$
is continuous with respect to the topology of
 $\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
, which is finer than the topology of the pseudometric
 ${{d}}^{{({\alpha })}}$
(Rem. 4.16). Assume that
 $\textit {img}\:(\gamma )\subseteq \textit {dom}\:(\phi )$
for some standard chart
 $\phi$
; by Rem. 3.10, we have
 \begin{equation} \int _{x}^{y}{{|\gamma '(t)|}}_{{{\alpha }}}\: dt = \int _{x}^{y}{{|(\phi \circ \gamma )'(t)|}}_{{|(\phi \circ \gamma )'(t)|}{{\alpha }}}\: dt . \end{equation}
For a sufficiently fine subdivision
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}$
of
 $\textit {dom}\:(\gamma )$
, we have (Prop. 4.21)
 \begin{equation} \sum _{i=1}^k{{d}}^{{({\alpha })}}(\gamma ({{t}}_{{{i}}}),\gamma ({{t}}_{{{i-1}}})) = \sum _{i=1}^k|\phi \circ \gamma ({{t}}_{{{i}}})-\phi \circ \gamma ({{t}}_{{{i-1}}}){{|}}_{{|}{{\alpha }}} . \end{equation}
By a standard result about smooth paths on
 ${\mathbb{R}}^n$
, the sum
 $ \int _{x}^{y}{{|(\phi \circ \gamma )'(t)|}}_{{|(\phi \circ \gamma )'(t)|}{{\alpha }}} dt$
(right member of (5)) is the least upper bound of the sums
 $ \sum _{i=1}^k|\phi \circ \gamma ({{t}}_{{{i}}})-\phi \circ \gamma ({{t}}_{{{i-1}}}){{|}}_{{|}{{\alpha }}}$
(right member of (6)) for
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}$
running through the set of subdivisions of
 $\textit {dom}\:(\gamma )$
. The above-mentioned result is given in (Papadopoulos Reference Papadopoulos2013, Prop. 1.3.1) for
 $\alpha =2$
, although the proof is obviously valid for any
 $\alpha \in [{{1}},{{\infty }}]$
. We no longer assume that
 $\textit {dom}\:(\gamma )$
is contained in the domain of a standard chart. Since
 $\textit {dom}\:(\gamma )$
is compact and the domains of the standard charts form an open covering of
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
, we have a subdivision
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}$
of
 $\textit {dom}\:(\gamma )$
such that for all
 $i\in \{{1},\ldots ,{k}\}$
, the restriction of
 $\gamma$
to
 $[{{{{t}}_{{{i}}}}},{{{{t}}_{{{i-1}}}}}]$
is contained in the domain of some standard chart.
We suppose that the graphs
 ${{G}}_{{1},\ldots ,{{G}}_{n}}$
in the statements of Lem. 4.25 and Thm. 4.26 are associated with the sequential processes of some program
 $P$
(Def. 2.2), which means that they all satisfy the following property: every vertex with at least two outgoing (resp. incoming) arrows has at least one incoming (resp. outgoing) arrow.
Lemma 4.25.
For every piecewise affine map
 $\gamma$
from
 $p$
to
 $q$
on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
(Def. 4.4) and every
 $\varepsilon \gt 0$
, there exists a piecewise smooth path
 $\delta$
from
 $p'$
to
 $q'$
on
 $\mathcal{A}_{{{{G}}_{{{1}}}}} \times \cdots \times \mathcal{A}_{{{{G}}_{{{n}}}}}$
(Def. A.7) such that the images of
 $p$
and
 $q$
under
 ${{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}}$
are
 $p'$
and
 $q'$
, and
 ${\mathcal L}^{\alpha }(\delta )\leqslant L^{\alpha }(\gamma )+\varepsilon$
. If
 $\gamma$
is directed (Def. 2.11), then we can suppose that
 ${\mathcal L}^{\alpha }(\delta )=L^{\alpha }(\gamma )$
.
Proof.
Without loss of generality, we assume that all the steps appearing in
 $\gamma$
are non-constant.
Fix
 ${{t}}_{{{0}}}\in \textit {dom}\:(\gamma )$
and choose a compact interval
 $I$
, neighborhood of
 ${{t}}_{{{0}}}$
, such that
 $\gamma (I\setminus \{{{t}}_{{{0}}}\})$
does not contain any vertex.
If
 $\gamma ({{t}}_{{{0}}})$
is not a vertex, then for every
 $t\in I$
, both
 $|{G}|$
and
 $\|{G}\|$
contain
 $\gamma (t)$
, which is the only element of
 $\|{G}\|$
satisfying
 ${\beta }_G(\gamma (t))=\gamma (t)$
. Hence the mapping
 $\delta :t\in I\mapsto \gamma (t)\in \|{G}\|$
is smooth (because it is affine) and satisfies
 ${\beta }_G\circ \delta ={{{\gamma }|}}_{}I$
.
Now suppose that
 $\gamma ({{t}}_{{{0}}})$
is a vertex. It occurs at the junction between two consecutive steps
 $s$
and
 $s'$
of the piecewise affine path
 $\gamma$
. Hence the supports
 $a$
and
 $a'$
of
 $s$
and
 $s'$
are uniquely defined, and each of the steps
 $s$
and
 $s'$
is either directed or antidirected (Def. 4.3).
If both
 $s$
and
 $s'$
are directed (resp. antidirected.), then
 $\textrm {tgt}\; a=\textrm {src}\ a'$
(resp.
 $\textrm {src}\ a=\textrm {tgt}\; a'$
). The mapping
 $\delta :I\to \|{G}\|$
sending
 $t\not ={{t}}_{{{0}}}$
to the unique lifting of
 $\gamma (t)$
, and
 ${{t}}_{{{0}}}$
to the traversal
 $(a,a')$
(resp.
 $(a',a)$
) is piecewise smooth. As before, we have
 ${\beta }_G\circ \delta ={{{\gamma }|}}_{}I$
.
If
 $s$
is directed while
 $s'$
is antidirected (the dual case is dealt with in the same way), then we have
 $\textrm {tgt}\; a=\textrm {tgt}\ s=\textrm {src}\ s'=\textrm {tgt}\; a'$
. If
 $a=a'$
, then we can shorten both
 $s$
and
 $s'$
so that they no longer visit
 $\textrm {tgt}\; a$
, this shortens the path
 $\gamma$
without changing its source or its target. If
 $a\not =a'$
, then the vertex
 $\textrm {tgt}\; a$
has at least two incoming arrows, and by the assumption made in Def. 2.2, it also has an outgoing arrow
 $b$
. On
 ${{I}}_{{{-}}}=I\:\cap \:]{{-\infty }},{{{{t}}_{{{0}}}}}]$
, we define
 ${{\delta }}_{{{1}}}$
to be the path sending
 $t$
to
 $\gamma (t)$
for
 $t\not ={{t}}_{{{0}}}$
; and
 ${{t}}_{{{0}}}$
to
 $(a,b)$
. We have
 ${\beta }_G\circ {{\delta }}_{{{1}}}={{{\gamma }|}}_{{{{I_-}}}}$
. On
 ${{I}}_{{{+}}}=I\cap [{{{{t}}_{{{0}}}}},{{\infty }}[$
, we define the path
 ${{\delta }}_{{{3}}}$
sending
 $t$
to
 $\gamma (t)$
for
 $t\not ={{t}}_{{{0}}}$
; and
 ${{t}}_{{{0}}}$
to
 $(a',b)$
. We have
 ${\beta }_G\circ {{\delta }}_{{{3}}}={{{\gamma }|}}_{{{{I_+}}}}$
. The paths
 ${{\delta }}_{{{1}}}$
and
 ${{\delta }}_{{{3}}}$
are smooth and we have
 $({\beta }_G\circ {{\delta }}_{{{1}}})\cdot ({\beta }_G\circ {{\delta }}_{{{3}}})={{{\gamma }|}}_{}I$
.
As in Ex. 4.23, we have an arbitrarily short piecewise smooth path
 ${{\delta }}_{{{2}}}$
joining the traversals
 $(b,a)$
and
 $(b,a')$
(apart from these traversals,
 ${{\delta }}_{{{2}}}$
covers
 $\{b\} \times ]{{0}},{{\varepsilon '/2}}[$
with
 $\varepsilon '$
being the length of
 ${{\delta }}_{{{2}}}$
). A path arising in that context is called a patch.
We have thus one of three situations: i)
 $\gamma ({{t}}_{{{0}}})$
is not a vertex, ii)
 $\gamma ({{t}}_{{{0}}})$
is a vertex and
 $a$
and
 $a'$
go in the same direction, and iii)
 $\gamma ({{t}}_{{{0}}})$
is a vertex and
 $a$
and
 $a'$
go in opposite directions. Note that if
 $\gamma$
is directed, then the case iii) does not occur. In cases i) and ii), we define
 ${{\delta }}_{{{1}}}={{{\delta }|}}_{{{{I_-}}}}$
and
 ${{\delta }}_{{{3}}}={{{\delta }|}}_{{{{I_+}}}}$
, so the concatenation
 ${{\delta }}_{{{1}}}{{\delta }}_{{{3}}}=\delta$
makes sense. In case iii), we need a patch
 ${{\delta }}_2$
to form the piecewise smooth concatenation
 ${{\delta }}_{{{1}}}{{\delta }}_{{{2}}}({{\delta }}_{{{3}}}\circ (t\in J\mapsto t-\varepsilon '\in {{I}}_{{{+}}}))$
with
 $J={{I}}_{{{+}}}+\varepsilon '$
. Hence, we have piecewise smooth paths
 ${{\delta }}_{{{1}}}$
,
 ${{\delta }}_{{{2}}}$
, and
 ${{\delta }}_{{{3}}}$
such that
-
(1)
$({\beta }_G\circ {{\delta }}_{{{1}}})={{{\gamma }|}}_{{{{I_-}}}}$
and
$({\beta }_G\circ {{\delta }}_{{{3}}})={{{\gamma }|}}_{{{{I_+}}}}$
, -
(2) in cases i) and ii),
$\textit {dom}\:({{\delta }}_{{{2}}})=\{{{t}}_{{{0}}}\}$
and
$\delta ={{\delta }}_{{{1}}}{{\delta }}_{{{3}}}$
is piecewise smooth, and -
(3) in case iii),
${\mathcal L}^{{\alpha }}({{\delta }}_{{{2}}})$
is arbitrarily small and
$\delta ={{\delta }}_{{{1}}}{{\delta }}_{{{2}}}({{\delta }}_{{{3}}}\circ \theta ))$
is piecewise smooth with
$J={{I}}_{{{+}}}+{\mathcal L}^{{\alpha }}({{\delta }}_{{{2}}})$
and
$\theta :t\in J\mapsto t-{\mathcal L}^{{\alpha }}({{\delta }}_{{{2}}})\in {{I}}_{{{+}}}$
.


In higher dimensions, we have
 $\gamma ={{\gamma }}_{1}{ \times }\cdots { \times }{{\gamma }}_{n}$
. We can choose
 $I$
so that for every
 $k\in \{{1},\ldots ,{n}\}$
, the set
 ${{\gamma }}_k(I\setminus \{{{t}}_{{{0}}}\})$
does not contain any vertex. By applying the above reasoning for every
 $k\in \{{1},\ldots ,{n}\}$
, we obtain the piecewise smooth paths
 ${{\delta }}_1^{{(k)}}$
,
 ${{\delta }}_2^{{(k)}}$
,
 ${{\delta }}_3^{{(k)}}$
satisfying 1), 2), and 3) with respect to
 ${{\gamma }}_k$
. We form the products
 ${{\delta }}_{{{1}}}={{\delta }}_{{{1}}}^{{({1})}} \times \cdots \times {{\delta }}_{{{1}}}^{{({n})}}$
,
 ${{\delta }}_{{{2}}}={{\delta }}_{{{2}}}^{{({1})}} \times \cdots \times {{\delta }}_{{{2}}}^{{({n})}}$
, and
 ${{\delta }}_{{{3}}}={{\delta }}_{{{3}}}^{{({1})}} \times \cdots \times {{\delta }}_{{{3}}}^{{({n})}}$
. We have
 $({{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}})\circ {{\delta }}_{{{1}}}={{{\gamma }|}}_{{{{I_-}}}}$
and
 $({{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}})\circ {{\delta }}_{{{3}}}={{{\gamma }|}}_{{{{I_+}}}}$
because the equalities hold componentwise. We have
 $L^{\alpha }(({{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}})\circ {{\delta }}_j)=L^{\alpha }({{\delta }}_j)={\mathcal L}^{\alpha }({{\delta }}_j)$
for
 $j\in \{1,2,3\}$
(Rem. 4.19 and Lem. 4.24). Therefore,
 $L^{\alpha }({{{\gamma }|}}_{}I)={\mathcal L}^{\alpha }({{\delta }}_{{{1}}})+{\mathcal L}^{\alpha }({{\delta }}_{{{3}}})$
. If
 $\gamma$
is directed, then so are all the paths
 ${{\gamma }}_k$
, consequently the case iii) does not occur, and we have
 $L^{\alpha }({{{\gamma }|}}_{}I)={\mathcal L}^{\alpha }({{\delta }}_{{{1}}}{{\delta }}_{{{3}}})$
. Otherwise the case iii) may occur, so we cannot ignore the patch
 ${{\delta }}_{{{2}}}$
. Yet, in each coordinate,
 ${\mathcal L}^{\alpha }({{\delta }}_{{{2}}}^{{({k})}})$
can be made arbitrarily small. We choose a domain of definition common to all the patches
 ${{\delta }}_{{{2}}}^{{({k})}}$
(some of them are “useless” loops if we are not in the case iii) for
 ${{\gamma }}_k$
at
 ${{t}}_{{{0}}}$
). In particular, we have the shift
 $\theta ={{\theta }}_{{{1}}} \times \cdots \times {{\theta }}_n$
, and
 ${\mathcal L}^{{\alpha }}({{\delta }}_{{{1}}}{{\delta }}_{{{2}}}({{\delta }}_{{{3}}}\circ \theta ))=L^{\alpha }({{{\gamma }|}}_{}I)+{\mathcal L}^{{\alpha }}({{\delta }}_{{{2}}})$
(keeping in mind that
 ${\mathcal L}^{{\alpha }}({{\delta }}_{{{3}}}\circ \theta )={\mathcal L}^{{\alpha }}({{\delta }}_{{{3}}})$
, see Rem. B.7). We have
 ${\mathcal L}^{{\alpha }}({{\delta }}_{{{2}}})\leqslant {\mathcal L}({{\delta }}_{{{2}}})$
as an immediate consequence of the Jensen inequality (Brokate and Kersting Reference Brokate and Kersting2015, 5.7) so making each component
 ${{\delta }}_2^{{({k})}}k$
arbitrarily small guarantees that so is
 ${\mathcal L}^{{\alpha }}({{\delta }}_{{{2}}})$
.
Theorem 4.26.
Let
 $p$
and
 $q$
be the images under
 ${{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}}$
of
 $p'$
and
 $q'$
, we have
 \begin{equation*} {{d}}^{{({\alpha })}}(p,q) = \inf \big \{\:{\mathcal L}^{\alpha }(\delta )\ \big |\ \big \} \delta \text{ piecewise smooth path from } p' \text{ to } q'\:. \end{equation*}
Proof.
We have
 ${{d}}^{{({\alpha })}}(p,q) = \inf \big \{\:L^{\alpha }(\gamma )\ \big |\ \big \}{\gamma \text{ path from } p \text{ to } q\:}$
because
 ${{d}}^{{({\alpha })}}$
is intrinsic (Lem. 4.20). We have
 $ L^{\alpha }(({{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}})\circ \delta ) = L^{\alpha }(\delta ) = {\mathcal L}^{\alpha }(\delta )$
for every piecewise smooth path
 $\delta$
from
 $p'$
to
 $q'$
(Rem. 4.19 and Lem. 4.24). Therefore,
 ${{d}}^{{({\alpha })}}(p,q)$
is less than the infimum of the values
 ${\mathcal L}^{\alpha }(\delta )$
; the converse inequality holds by Lem. 4.25.
5. Local Orders
Local orders (§5.2) are based on ordered spaces (§5.1) as atlases on charts; see (Coursolle and Haucourt Reference Coursolle and Haucourt2024, §3) for a detailed study. They are used in concurrency theory (Fajstrup et al. (Reference Fajstrup, Goubault and Raussen2006)) in a manner similar to that in which “finite causal orientations”Footnote 3 are used in cosmology (Segal Reference Segal1976, p. 23). The importance of local antisymmetry and corresponding technical difficulties is coined in (Lawson Reference Lawson1989, p. 277): «We will be particularly interested in the case that the conal order is antisymmetric […] determining whether or not it [the conal order] is antisymmetric can be quite delicate», see also §5.4.
For every graph
 $G$
, we equip the sets
 $|{G}|$
and
 $\|{G}\|$
(Def. 2.6 and 2.15) with the standard local orders
 $\mathcal{X}_{{G}}$
and
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
(Def. 5.11 and 5.15). It follows that the geometric model
 $|{P}|$
of a conservative program
 $P$
(Def. 2.13) is a tile-compatible sub-local order of the product
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
, with
 ${{G}}_{{{i}}}$
denoting the underlying graph of the
 $i^{th}$
sequential process of
 $P$
(Def. 2.2). Similarly, the smooth model of
 $P$
(Def. 2.22) induces a sub-local order
 $\|{P}\|$
of the product
 $\tilde {\mathcal{X}}_{G_{1}} \times \cdots \times \tilde {\mathcal{X}}_{G_{n}}$
.
On the one hand, the product of blowups
 ${{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_1}}}:\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|\to |{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
(Def. 2.15) induces a Euclidean local embedding (Def. 5.6) from
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_{1}}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_{n}}}$
to
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
, which is universal (Thm. 5.33). On the other hand, Lawson’s correspondence (Thm. 5.41) relates
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_{1}}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_{n}}}$
to the standard parallelized atlas
 $(\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}},({{f}}_{{1},\ldots ,{{f}}_{n}}))$
(Def. 3.3 and 3.6).
What makes
 $|{P}|$
relevant to concurrency theory is the relation between the execution traces of
 $P$
(Def. 2.3) and the directed paths on
 $|{P}|$
(Def. 5.7):
-
(1) We can always assume that an execution trace
${{p}}_{{0},\ldots ,{{p}}_{k}}$
of
$P$
is contained in its discrete model
${{[[{{P}}]]}}_{{{d}}}$
(Def. 2.5 (2)). -
(2) By “joining” the middles of the tiles
${{\tau }}_{{0},\ldots ,{{\tau }}_{k}}$
corresponding to
${{p}}_{{0},\ldots ,{{p}}_{k}}$
(Def. 2.11), we obtain
$\gamma$
a piecewise linear lifting of
${{p}}_{{0},\ldots ,{{p}}_{k}}$
on
$|{P}|$
(Haucourt Reference Haucourt2018, Def. 6.2).


This relation extends to the directed paths on
 $\|{P}\|$
(i.e. the piecewise smooth maps
 $\sigma$
from some compact interval to
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
with values in
 $\|{P}\|$
, and whose derivative at every
 $t$
has non-negative coordinates in the basis
 $({{f}}_{{{1}}}\circ \sigma (t),\ldots ,{{f}}_{{{n}}}\circ \sigma (t))$
):
-
(3) The directed path
$\gamma$
from (2) is lifted along
${{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_1}}}$
to
$\tilde \gamma$
a piecewise linear directed path on
$\,{\tilde {\mathcal{\!\!X}}}_{{G_{1}}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_{n}}}$
(Thm. 5.29); in particular,
$\textit {img}\:(\tilde \gamma )\subseteq \|{P}\|$
. -
(4) By the Lawson’s correspondence (Thm. 5.41), the path
$\tilde \gamma$
is directed on the standard parallelized atlas
$(\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}},({{f}}_{{1},\ldots ,{{f}}_{n}}))$
.


To sum up, every execution trace of a conservative program
 $P$
is represented by a piecewise linear (therefore piecewise smooth) directed path on
 $(\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}},({{f}}_{{1},\ldots ,{{f}}_{n}}))$
whose image is included in the smooth model of
 $P$
.
5.1 Ordered spaces and pospaces
An ordered space is a topological space
 $X$
together with a partial order
 $\leqslant$
on its underlying set
 $|X|$
; the partial order
 $\leqslant$
is said to be closed when so is the subset
 $\{(a,b)\in X \times X\mid a\leqslant b\}$
of the product space
 $X \times X$
. A chain of
 $(X,\leqslant )$
is a totally ordered subposet of
 $(X,\leqslant )$
, it is said to be unbounded when it has neither greatest nor least element. A Nachbin ordered space, or pospace, is a topological space with a closed partial order on it; the closedness condition follows (Nachbin Reference Nachbin1965, p. 25), although the term “pospace” appeared later (Gierz et al. Reference Gierz, Hofmann, Keimel, Lawson, Mislove and Scott1980, VI-1.1, p. 271–272). The real line
 $\mathbb{R}$
with its standard topology and order is a prototypical example of a pospace. A pospace
 $X_{{}}'$
such that
 $|X'|\subseteq |X|$
is said to be a subpospace of
 $X_{{}}$
when
 $X_{{}}'$
is both a subspace and a subposet of
 $X_{{}}$
, that is
-
– the open subsets of
$X_{{}}'$
are the restrictions to
$X_{{}}'$
of the open subsets of
$X_{{}}$
, and -
– the partial order of
$X_{{}}'$
is the restriction to
$X_{{}}'$
of the partial order of
$X_{{}}$
.


Every subset of
 $|X_{{}}|$
induces a subpospace of
 $X_{{}}$
. If this subset is open in
 $X_{{}}$
, then the subpospace is said to be open. A subset
 $C$
of a poset
 $(X,\leqslant )$
is said to be order convex when for all
 $a$
,
 $b\in C$
, we have
 $\{x\in X\mid a\leqslant x\leqslant b\}\subseteq C$
. A pospace
 $(X,\leqslant )$
is said to be locally order convex when its underlying topology has a basis of order convex open subset, see (Nachbin Reference Nachbin1965, p. 26), or (Gierz et al. Reference Gierz, Hofmann, Keimel, Lawson, Mislove and Scott1980, VI-1.5, p. 273).
A morphism of ordered spaces is an order-preserving continuous map. An isomorphism of ordered spaces is called a dihomeomorphism. The product of two ordered spaces
 $X$
and
 $Y$
is the product of their topological spaces together with the product order; if
 $X$
and
 $Y$
are pospaces, then so is their product.
An embedding of ordered spaces is a morphism of ordered spaces that induces a dihomeomorphism on its image.
Definition 5.1.
The left action of the
 $n^{th}$
symmetric group
 $\mathfrak S_n$
on
 $n$
-tuples is defined by
 \begin{equation*} \sigma \cdot ({{t}}_{{1},\ldots ,{{t}}_{n}}) = ({{t}}_{{{{{\sigma }}^{{-1}}1}}},\ldots ,{{t}}_{{{{{\sigma }}^{{-1}}n}}}) . \end{equation*}
By extension, for every
 $n$
-tuple of sets
 $(A_1,\ldots ,A_n)$
, we define the set
 $\sigma \cdot (A_1 \times \cdots \times A_n)$
as the product
 $A_{{{\sigma }}^{{-1}}1} \times \ldots \times A_{{{\sigma }}^{{-1}}n}$
and the map
 $\pi _\sigma :A_1 \times \cdots \times A_n\to \sigma \cdot (A_1 \times \cdots \times A_n)$
by
 $\pi _\sigma (t)=\sigma \cdot t$
. In particular, for every
 $n$
-tuple of mappings
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
, we have
 \begin{equation} \pi _\sigma \circ ({{f}}_{1}{ \times }\cdots { \times }{{f}}_{n}) = ({{f}}_{{{{{\sigma }}^{{-1}}1}}} \times \cdots \times {{f}}_{{{{{\sigma }}^{{-1}}n}}})\circ \pi _\sigma \end{equation}
taking care that
 $\pi _\sigma$
on the right-hand side of (
7
) permutes the domains of the mappings
 $f_k$
, while
 $\pi _\sigma$
on the left-hand side permutes their codomains.
The next result is an immediate consequence of the second point of (Schröder Reference Schröder2003, 10.4.10), which is about (possibly infinite) products of posets.
Lemma 5.2.
Every poset automorphism of
 ${\mathbb{R}}^n$
can be written as
 $({{x}}_{1}{ \times }\cdots { \times }{{x}}_{n})\circ \pi _{\sigma }$
with
 $\sigma \in \mathfrak S_n$
and
 ${{x}}_{{{k}}}\in \text{Aut}({\mathbb{R}})$
for
 $k\in \{{1},\ldots ,{n}\}$
.
Remark 5.3.
The groups
 $(\text{Aut}\,{\mathbb{R}})^n$
and
 $\mathfrak S_n$
are canonically identified with the subgroups
 $A=\{{{x}}_{1}{ \times }\cdots { \times }{{x}}_{n}\mid {{x}}_{{{k}}}\in \text{Aut}\,{\mathbb{R}};\,k\in \{{1},\ldots ,{n}\}\}$
and
 $B=\{{{\pi }}_{{{\sigma }}}\mid \sigma \in \mathfrak S_n\}$
of
 $\text{Aut}({\mathbb{R}}^n)$
. Lem. 5.2 exactly states that
 $A\circ B=\text{Aut}({\mathbb{R}}^n)$
and it is clear that
 $A\cap B=\{{{id}}_{{{{\mathbb{R}}^n}}}\}$
. We deduce from (
7
) and (Grillet Reference Grillet2007
, Prop. 4.5, p. 19) that the subgroup
 $A$
is normal. Hence
 $\text{Aut}({\mathbb{R}}^n)$
is the semidirect product
 $(\text{Aut}\,{\mathbb{R}})^n\rtimes \mathfrak S_n$
(Grillet Reference Grillet2007
, Prop. 11.2, p. 93); so the decomposition given by Lem. 5.2 is unique.
The binary greatest lower bound operator in
 ${\mathbb{R}}^n$
is denoted by
 $\wedge$
and its dual by
 $\vee$
. For every
 $i\in \{{1},\ldots ,{n}\}$
, the map
 ${{\text{pr}}}_{{{i}}}:{\mathbb{R}}^n\to {\mathbb{R}}$
is the
 $i^{th}$
projection. For every
 $x\in {\mathbb{R}}^n$
, we set
 $\downarrow x=\{y\in {\mathbb{R}}^n\mid y\leqslant x\}$
and
 $\uparrow x=\{y\in {\mathbb{R}}^n\mid x\leqslant y\}$
with
 $\leqslant$
the usual product order on
 ${\mathbb{R}}^n$
.
Definition 5.4.
A map
 $f:X\to Y$
between topological spaces
 $X$
and
 $Y$
is said to be open when
 $f(U)$
is open in
 $Y$
for every
 $U$
open in
 $X$
; an embedding (of
 $X$
into
 $Y$
) when it induces a homeomorphism onto its image; a local embedding when for every
 $x\in X$
, it induces an embedding of some open neighborhood
 $U$
of
 $x$
into
 $Y$
; a local homeomorphism when it is an open local embedding.
Lemma 5.5.
A pospace embedding
 $\theta :{\mathbb{R}}^n\to {\mathbb{R}}^n$
preserves existing least upper bounds (resp. greatest lower bounds) and its image is a set product of open intervals of
 $\mathbb{R}$
.
Proof.
The map
 $\theta$
is open (Def. 5.4) by invariance of domain (Hatcher Reference Hatcher2002, Thm. 2B.3, p. 172). Moreover, for every
 $t\in {\mathbb{R}}^n$
, we have a tuple
 $({{J}}_{{1},\ldots ,{{J}}_{n}})$
of open intervals of
 $\mathbb{R}$
such that
 $\theta (t)\in {{J}}_{1}{ \times }\cdots { \times }{{J}}_{n}\subseteq \textit {img}\:(\theta )$
. Given
 $u\in {\mathbb{R}}^n$
such that
 $\theta (t)\lt u$
, we have
 $x\in {{J}}_{1}{ \times }\cdots { \times }{{J}}_{n}$
such that
 $\theta (t)\lt x\lt u$
(by definition of the product order on
 ${\mathbb{R}}^n$
). Since
 $x\in {{J}}_{1}{ \times }\cdots { \times }{{J}}_{n}\subseteq \textit {img}\:(\theta )$
and
 $\theta$
is an embedding, we have
 $t\lt {{\theta }}^{{-1}}(x)$
. We have proven that:
 \begin{equation} \text{for every}\ t, u\in {\mathbb{R}}^n\ \text{such that}\ \theta (t)\lt u,\ \text{there exists}\ t'\gt t\ \text{such that}\ \theta (t)\lt \theta (t')\lt u. \end{equation}
The dual statement (obtained by exchanging the roles of
 $\lt$
and
 $\gt$
) is also valid, for similar reasons.
Let
 $\mathcal F$
be a subset of
 ${\mathbb{R}}^n$
with a least upper bound. Then
 $\theta (\!\sup \mathcal F)$
is an upper bound of
 $\theta (\mathcal F)$
because
 $\theta$
is order-preserving, so
 $\theta (\mathcal F)$
has a least upper bound and we have
 $\theta (\!\sup \mathcal F) \geqslant \sup \theta (\mathcal F)$
. Suppose that
 $\theta (\!\sup \mathcal F) \neq \sup \theta (\mathcal F)$
. By applying the dual of (8), we have
 $t\lt \sup \mathcal F$
such that
 $\theta (\!\sup \mathcal F)\gt \theta (t)\gt \sup \theta (\mathcal F)$
. From the latter inequalities and the fact that
 $\theta$
is a pospace embedding, we deduce that
 $t$
is an upper bound of
 $\mathcal F$
, which contradicts the fact that
 $t\lt \sup \mathcal F$
. Similarly, we prove that
 $\theta$
preserves existing greatest lower bounds.
For every
 $k\in \{{1},\ldots ,{n}\}$
, let
 ${{\theta }}_k={{\text{pr}}}_{{{k}}}\circ \theta$
and
 ${{I}}_{{{k}}}=\textit {img}\:({{\theta }}_k)$
. Each
 ${{\theta }}_k$
is thus an open continuous map as a composite of such maps, hence each
 ${{I}}_{{{k}}}$
is an open interval. Let
 $x=({{x}}_{{1},\ldots ,{{x}}_{n}})\in {{I}}_{1}{ \times }\cdots { \times }{{I}}_{n}$
and
 $\mathcal F={{\theta }}^{{-1}}(\downarrow x)$
. For every
 $k\in \{{1},\ldots ,{n}\}$
, there exists
 ${{t}}^{{({k})}}\in {\mathbb{R}}^n$
such that
 ${{\theta }}_k({{t}}^{{({k})}})={{x}}_{{{k}}}$
, from which we deduce that
 \begin{equation*}\left \{ \begin{gathered} \quad {{\theta }}_k({{t}}^{{({1})}}\wedge \cdots \wedge {{t}}^{{({n})}}) \quad \leqslant \quad {{\theta }}_k({{t}}^{{({1})}})\wedge \cdots \wedge {{\theta }}_k({{t}}^{{({n})}}) \quad \leqslant \quad {{x}}_{{{k}}}\\ \quad {{\theta }}_k({{t}}^{{({1})}}\vee \cdots \vee {{t}}^{{({n})}}) \quad \geqslant \quad {{\theta }}_k({{t}}^{{({1})}})\vee \cdots \vee {{\theta }}_k({{t}}^{{({n})}}) \quad \geqslant \quad {{x}}_{{{k}}} \end{gathered} \right .\end{equation*}
It follows that
 ${{t}}^{{({1})}}\vee \cdots \vee {{t}}^{{({n})}}$
is an upper bound of
 $\mathcal F$
which is nonempty because it contains
 ${{t}}^{{({1})}}\wedge \cdots \wedge {{t}}^{{({n})}}$
; therefore
 $\sup \mathcal F$
exists. By definition of
 $\mathcal F$
, we have
 $\theta (\mathcal F)\subseteq \:\downarrow x$
, hence
 $\sup (\theta (\mathcal F))\leqslant x$
. We deduce that
 $\theta (\!\sup \mathcal F)\leqslant x$
because (we have already proven that)
 $\theta (\!\sup (\mathcal F))=\sup (\theta (\mathcal F))$
. Suppose that
 $\theta (\!\sup (\mathcal F))\neq x$
. By applying (8), we have
 $t\gt \sup \mathcal F$
such that
 $\theta (\!\sup (\mathcal F))\lt \theta (t)\lt x$
. From the latter inequalities and the fact that
 $\theta$
is a pospace embedding, we deduce that
 $t$
belongs to
 ${{\theta }}^{{-1}}(\downarrow x)=\mathcal F$
, which contradicts the fact that
 $t\gt \sup \mathcal F$
.
5.2 Local orders
A witness of compatibility of the ordered spaces
 $X_{{}}$
and
 $X_{{}}'$
around
 $p\in X\cap X'$
is a set
 $W$
containing
 $p$
that is open in both
 $X$
and
 $X'$
, and on which both
 $X_{{}}$
and
 $X_{{}}'$
induce the same ordered space. We say that
 $X_{{}}$
and
 $X_{{}}'$
are compatible around the point
 $p$
, which we denote by
 $X_{{}}\sim \kern -0.45em {p}\ X_{{}}'$
, when
 $p\not \in X_{{}}\cap {X_{{}}'}$
or such a witness exists. We say that
 $X_{{}}$
and
 $X_{{}}'$
are compatible when they are so around every point, in that case, we write
 $X_{{}}\sim X_{{}}'$
.
A local order (resp. Nachbin local order)
 $\mathcal{X}_{{}}$
is a collection of pairwise compatible ordered spaces (resp. pospaces); its underlying set
 $|{\mathcal{X}_{{}}}|$
is the union of the underlying sets of the elements of
 $\mathcal{X}_{{}}$
. A local order
 $\mathcal{X}_{{}}$
is said to be Euclidean of dimension
 $n$
when, for every
 $p\in |\mathcal{X}_{{}}|$
, there exists
 $X\in \mathcal{X}_{{}}$
in which
 $p$
has a neighborhood that is dihomeomorphic to
 ${\mathbb{R}}^n$
. The canonical local order induced by an ordered space
 $X$
is the one element set
 $\{X\}$
.
Definition 5.6.
A morphism (resp. local embedding) of local orders from
 $\mathcal{X}_{{}}$
to
 $\mathcal{Y}_{{}}$
is a mapping
 $f:|{\mathcal{X}_{{}}}|\to |{\mathcal{Y}_{{}}}|$
such that for every
 $p\in |{\mathcal{X}_{{}}}|$
, every
 ${Y_{{}}}\in \mathcal{Y}_{{}}$
and every open subset
 $V$
of
 $Y_{{}}$
containing
 $f(p)$
, there exists
 ${X_{{}}}\in \mathcal{X}_{{}}$
and an open subset
 $U$
of
 $X_{{}}$
containing
 $p$
such that
 $f(U)\subseteq V$
, and the restriction
 ${{{f}|}}_{{{{U}}}}:U\to V$
is order preserving, that is, for all
 $a,b\in U$
,
 $a\sqsubseteq _{X_{{}}}b\ \Rightarrow \ fa\sqsubseteq _{Y_{{}}}fb$
(resp.
 ${{{f}|}}_{{{{U}}}}:U\to V$
is an embedding). We say that
 $f$
is Euclidean of dimension
 $n\in \mathbb{N}$
when so is
 $\mathcal{X}_{{}}$
. A local dihomeomorphism is an open local embedding. Given
 $X\in \mathcal{X}_{{}}$
, the inclusion
 $|X|\subseteq |\mathcal{X}_{{}}|$
induces a local dihomeomorphism
 $\{X\}\hookrightarrow \mathcal{X}_{{}}$
. Local orders and their morphisms form the category
 $\mathbf{L}$
.
The Cartesian product of
 $\mathcal{X}_{{}}$
and
 $\mathcal{Y}_{{}}$
in
 $\mathbf{L}$
is the local order
 \begin{equation*} \mathcal{X}_{{}} \times \mathcal{Y}_{{}} = \big \{\:X \times Y\:\ \big |\ \:X\in \mathcal{X};\:Y\in \mathcal{Y}_{{}}\:\big \}. \end{equation*}
The topology (on the underlying set) of the local order
 $\mathcal{X}_{{}}$
is generated by the subsets
 $U$
that are open in some ordered space of the collection
 $\mathcal{X}_{{}}$
. The category of topological spaces is denoted by
 $\mathbf{Top}$
; the forgetful functor
 $\textit {Sp}:\mathbf{L}\to \mathbf{Top}$
sends every local order to its underlying topological space.
Two local orders
 $\mathcal{X}_{{}}$
and
 $\mathcal{Y}_{{}}$
are said to be equivalent, which we denote by
 $\mathcal{X}_{{}}\sim \mathcal{Y}_{{}}$
, when they have the same underlying set
 $S$
and the identity map
 ${id}_S$
induces an isomorphism between them. Assuming that
 $\mathcal{X}_{{}}$
and
 $\mathcal{Y}_{{}}$
have the same underlying set, we have
 $\mathcal{X}_{{}}\sim \mathcal{Y}_{{}}$
if, and only if, the union
 $\mathcal{X}_{{}}\cup \mathcal{Y}_{{}}$
is still a local order, which amounts to say that every
 $X\in \mathcal{X}_{{}}$
is compatible with every
 $Y\in \mathcal{Y}_{{}}$
(Coursolle and Haucourt Reference Coursolle and Haucourt2024, Prop. 3.25).
Definition 5.7.
A directed path on
 $\mathcal{X}_{{}}$
is a local order morphism from
 $\{[{{a}},{{b}}]\}$
to
 $\mathcal{X}_{{}}$
, with
 $a\leqslant b$
.
5.2.1 Standard local orders
The sets
 $|{G}|$
and
 $\|{G}\|$
, respectively, come with the standard local orders
 $\mathcal{X}_{{G}}$
and
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
, which we describe in this section.
Definition 5.8.
For every vertex
 $v$
, we define
 ${{U}}_{{{v}}}$
as the canonical star centered at
 $v$
(Def. 2.7), that is
 \begin{equation} {{U}}_{{{v}}} = \bigcup _{\textrm {tgt}\; a=v}\{a\} \times {{J}}_{{{a}}} \quad \cup \quad \{v\}\quad \cup \quad \bigcup _{\textrm {src}\; b=v}\{b\} \times {{I}}_{{{b}}} \end{equation}
with the intervals
 ${{J}}_{{{a}}}=\:]{{\tfrac {\ell (a)}2}},{{\ell (a)}}[$
and
 ${{I}}_{{{b}}}=\:]{{0}},{{\tfrac {\ell (b)}2}}[$
(as in (
2
) p. 11). The set
 ${{U}}_{{{v}}}$
is provided with the greatest topology and the least partial order
 ${{\sqsubseteq }}_v$
making the maps
 \begin{equation*} \begin{gathered} {{\gamma }}_a\::\:t\:\in \:-{{I}}_{{{a}}}\cup \{0\} \quad \:\: \mapsto \quad \left \{ \begin{array}{ll} (a,t+\ell (a)) & \text{ if }t\not =0\\[1mm] \phantom {(}v & \text{ if } t=0 \end{array} \right . \:\in \:\:\:{{U}}_{{{v}}} \\[2mm] {{\delta }}_b\::\:t\:\in \:\{0\}\cup {{I}}_{{{b}}} \quad \:\: \mapsto \quad \left \{ \begin{array}{ll} (b,t) & \text{ if } t\not =0\\[1mm] \phantom {(}v & \text{ if }t=0 \end{array} \right . \:\in \:\:\:{{U}}_{{{v}}} \end{gathered} \end{equation*}
continuous and order-preserving for all arrows
 $a$
such that
 $\textrm {tgt}(a)=v$
and all arrows
 $b$
such that
 $\textrm {src}(b)=v$
. In particular, the maps
 ${{\gamma }}_a$
and
 ${{\delta }}_b$
are pospace embeddings. Note that for every traversal
 $(a,b)$
at
 $v$
, the union of the mappings
 ${{\gamma }}_a$
and
 ${{\delta }}_b$
is the pospace embedding
 \begin{equation} {{\xi }}_{{{ab}}}\::\: t\:\in \:-{{I}}_{{{a}}}\cup \{0\}\cup {{I}}_{{{b}}} \quad \:\: \mapsto \quad \left \{ \begin{array}{ll} (a,t+\ell (a)) & \text{if}\ t\lt 0\\[1mm] \phantom {(}v & \text{if }t=0\\[1mm] (b,t) & \text{if }t\gt 0 \end{array} \right . \:\in \:\:\:{{U}}_{{{v}}} . \end{equation}
The set
 ${{U}}_{{{v}}}$
comes with the map
 ${{\tau }}_v:{{U}}_{{{v}}}\to {\mathbb{R}}$
defined by
 ${{\tau }}_v(v)=0$
, and
 \begin{equation*} {{\tau }}_v(x,t) = \left \{ \begin{array}{ll} t-\ell (x) & \text{ if } t\in {{J}}_{{{x}}}\\[2mm] t & \text{ if } t\in {{I}}_{{{x}}} \end{array} \right .. \end{equation*}
We observe that
 ${{\tau }}_v(p)\leqslant 0$
(resp.
 $\geqslant 0$
) iff
 $p\:{{\sqsubseteq }}_v\:v$
(resp.
 $v\:{{\sqsubseteq }}_v\:p$
), and that
 ${{\tau }}_v$
induces poset isomorphisms from
 $\{a\} \times {{I}}_{{{a}}}$
(resp.
 $\{a\} \times {{J}}_{{{a}}}$
) to
 $\textit {dom}\:({{\delta }}_a)\setminus \{0\}$
(resp.
 $\textit {dom}\:({{\gamma }}_a)\setminus \{0\}$
). It follows that for every
 $p$
,
 $q\in {{U}}_{{{v}}}$
, we have
 $p\:{{\sqsubseteq }}_vq$
if, and only if (with the map
 ${{\pi }}_G$
from Def. 2.6)
 \begin{equation} {{\tau }}_vp\:\leqslant \:0\:\leqslant \:{{\tau }}_vq\quad \qquad \text{or}\qquad \quad {{\pi }}_Gp={{\pi }}_Gq \quad \text{and}\quad {{\tau }}_vp\:\leqslant \:{{\tau }}_vq. \end{equation}
In the first case,
 $p$
is before
 $v$
while
 $q$
is after
 $v$
. In the second one, we have
 $p=q=v$
, or both
 $p$
and
 $q$
belong to
 $\{a\} \times {{I}}_{{{a}}}$
or
 $\{a\} \times {{J}}_{{{a}}}$
with
 $a={{\pi }}_Gp$
. The relation
 ${{\sqsubseteq }}_v$
is a closed partial order on
 ${{U}}_{{{v}}}$
(closedness of this partial order is proven from an easy – but tedious – case disjunction readily obtained from the negation of the formula (
11
)). The standard pospace at
 $v$
is
 $({{U}}_{{{v}}},{{\sqsubseteq }}_v)$
.
Remark 5.9.
The stars centered at a vertex (Def. 2.7) and the sets of the form
 $\{a\} \times ]{{t-\varepsilon }},{{t+\varepsilon }}[$
are order convex in
 $({{U}}_{{{v}}},{{\sqsubseteq }}_v)$
, which is thus locally order convex (p. 21) by Rem. 2.9
.
Lemma 5.10.
The collection of pospaces
 $({{U}}_{{{v}}},{{\sqsubseteq }}_v)$
and
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
(equipped with the obvious pospace structure), with
 $v\in {{G}}^{{({0})}}$
and
 $a\in {{G}}^{{({1})}}$
, is a local order whose underlying set is
 $|{G}|$
.
Proof.
Every vertex and every middle point
 $(a,\ell (a)/2)$
belongs to a single element of the collection. Every point
 $(a,t)$
with
 $t\not =\ell (a)/2$
only belongs to
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
and
 ${{U}}_{{{v}}}$
with
 $v=\textrm {src}(a)$
or
 $v=\textrm {tgt}(a)$
depending on whether
 $t\lt \ell (a)/2$
or
 $t\gt \ell (a)/2$
. Hence the (nontrivial) witnesses of compatibility are the open sets
 $\{a\} \times ]{{0}},{{\ell (a)/2}}[$
and
 $\{a\} \times ]{{\ell (a)/2}},{{\ell (a)}}[$
.
Definition 5.11.
(Haucourt Reference Haucourt2018
, §6.1). The standard local order on
 $|{G}|$
(resp.
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
) is the collection
 $\mathcal{X}_{{G}}$
described in Lem. 5.10 (resp. the product
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
of such collections).
Remark 5.12.
The notion of a directed path on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
(Def. 2.11), and that of a directed path on
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
(Def. 5.7), are equivalent – see (Haucourt Reference Haucourt2012
, §6.2).
Remark 5.13.
Every open ball
 $B$
of
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
equipped with the
 ${{d}}^{{({\infty })}}$
metrics (Def. 4.17) is a product
 ${{B}}_{1}{ \times }\cdots { \times }{{B}}_{n}$
of open balls
 ${{B}}_{{{i}}}\subseteq |{{{G}}_{{{i}}}}|$
for
 $i\in \{{1},\ldots ,{n}\}$
. If
 $r\leqslant \tfrac R4$
with
 $r$
the radius of
 $B$
, then we have
 $X\in \mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
such that
 $B\subseteq X$
. Indeed, for each
 $i\in \{{1},\ldots ,{n}\}$
, if
 ${{B}}_{{{i}}}$
contains the vertex
 ${{v}}_{{{i}}}$
, then it is included in the standard pospace at
 ${{v}}_{{{i}}}$
(Def. 5.8 and Prop. B.22), otherwise
 ${{B}}_{{{i}}}\subseteq \{{{a}}_{{{i}}}\} \times ]{{0}},{{\ell ({{a}}_{{{i}}})}}[$
for some arrow
 ${{a}}_{{{i}}}$
of
 ${{G}}_{{{i}}}$
.
For our purpose, the only relevant local order on
 $|{G}|$
is the standard one (Def. 5.11); the case of
 $\|{G}\|$
is a little subtler because the properties of the local order morphism induced by the blowup
 ${\beta }_G:\|{G}\|\to |{G}|$
(Def. 2.15) strongly depend on the local order on
 $\|{G}\|$
.
Remark 5.14.
A directed path
 $\gamma$
(Def. 5.7) is a local embedding (in the sense of Def. 5.6) if, and only if, the path
 $\textit {Sp}(\gamma )$
(p. 23) is a local embedding (in the sense of Def. 5.4); moreover, it is Euclidean. In particular, if
 $j:[0,1]\to \textit {dom}\:(\gamma )$
is an increasing map such that
 $\gamma \circ j$
is an arc (such a
 $j$
exists by Lem. B.2), then
 $\gamma \circ j$
is a local embedding.
The standard charts
 ${{\phi }}_a$
and
 ${{\phi }}_{{{ab}}}$
(Def. 3.1), with
 $a$
and
 $(a,b)$
arrows and traversals, are bijections toward open subintervals of
 $\mathbb{R}$
. Their domains, namely
 $\textit {dom}\:{{{\phi }}_a}$
and
 $\textit {dom}\:{{{\phi }}_{{{ab}}}}$
, are equipped with the pospace structures so that
 ${{\phi }}_a$
and
 ${{\phi }}_{{{ab}}}$
become dihomeomorphisms. All these pospaces are locally order convex (p. 21) because so are the open intervals of
 $\mathbb{R}$
.
Definition 5.15.
The collection of pospaces
 $\textit {dom}\:{{{\phi }}_a}$
and
 $\textit {dom}\:{{{\phi }}_{{{ab}}}}$
(Def. 3.1), denoted by
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
, forms the standard local order on
 $\|{G}\|$
; the witnesses of compatibility are of the form
 $\{a\} \times {{J}}_{{{a}}}$
and
 $\{b\} \times {{I}}_{{{b}}}$
with
 $a$
,
 $b$
arrows of
 $G$
. The standard local order on the set
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
is
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_{1}}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_n}}$
.
Remark 5.16.
Given a traversal
 $(a,b)$
at
 $v$
,
 $\varepsilon \in \:]{{0}},{{\ell (a)}}[$
, and
 $\varepsilon '\in \:]{{0}},{{\ell (b)}}[$
, the blowup
 ${\beta }_G$
induces the canonical pospace isomorphism

hence a pospace embedding from
 $\textit {dom}\:{{{\phi }}_{{{ab}}}}$
to
 $({{U}}_{{{v}}},{{\sqsubseteq }}_v)$
(Def. 3.1 and 5.8). The domains of these embeddings together with the sets
 $\{a\} \times I$
with
 $I$
an open interval of
 $]{{0}},{{\ell (a)}}[$
form a base of the topology of
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
, so
 ${\beta }_G$
induces a Euclidean local embedding of
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
into
 $\mathcal{X}_{{G}}$
(Def. 5.6).
Definition 5.17.
For every vertex
 $v\in \|{G}\|$
, the standard partial order
 ${{\leqslant }}_v$
on
 ${{{\beta }_G}}^{{-1}}{{U}}_{{{v}}}$
is the one such that
 $x\:{{\leqslant }}_vy$
if, and only if,
 ${{\phi }}_{{{ab}}}(x)\leqslant {{\phi }}_{{{ab}}}(y)$
for some traversal
 $(a,b)$
at
 $v$
.
Remark 5.18.
Given a vertex
 $v\in \|{G}\|$
, the collection of sets
 $\textit {dom}\:({{\phi }}_{{{ab}}})$
for
 $(a,b)$
traversal at
 $v$
forms an open covering of
 ${{{\beta }_G}}^{{-1}}{{U}}_{{{v}}}$
so the inclusion of
 $\textit {dom}\:({{\phi }}_{{{ab}}})$
into
 $({{{\beta }_G}}^{{-1}}{{U}}_{{{v}}},{{\leqslant }}_v)$
is an open embedding of ordered spaces for every traversal
 $(a,b)$
at
 $v$
. Moreover, the map
 ${\beta }_G$
induces a Euclidean local embedding (Def. 5.6) of
 $\{({{{\beta }_G}}^{{-1}}{{U}}_{{{v}}},{{\leqslant }}_v)\}$
into
 $\{({{U}}_{{{v}}},{{\sqsubseteq }}_v)\}$
(Def. 5.8).
If the graph
 $G$
contains a singular traversal
 $(a,b)$
(Def. 2.14), then
 ${\beta }_G:\,{\tilde {\mathcal{\!\!X}}}_{{G}}\to \mathcal{X}_{{G}}$
is not open because, for
 $\varepsilon \gt 0$
sufficiently small,
 ${\beta }_G({{{{\phi }}_{{{ab}}}}}^{{-1}}(]{{-\varepsilon }},{{\varepsilon }}[))$
is not open (Def. 3.1). However, we observe that for every traversal
 $\tau$
at a vertex
 $v$
, the blowup
 ${\beta }_G$
induces a bijection from
 $({{U}}_{{{v}}}\setminus \{v\})\cup \{\tau \}$
to
 ${{U}}_{{{v}}}$
; we have an analog of Lem. 5.10:
Lemma 5.19.
The collection of subspaces
 $({{U}}_{{{v}}}\setminus \{v\})\cup \{\tau \}$
equipped with the partial orders induced by
 ${{({\beta }_G \times {\beta }_G)}}^{{-1}}({{\sqsubseteq }}_v)$
with
 $\tau$
a traversal at
 $v$
, and
 $({{U}}_{{{v}}},{{\sqsubseteq }}_v)$
given by Def. 5.8
, along with the subspaces
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
equipped with the obvious total orders, is a local order on
 $\|{G}\|$
.
Proof.
Given two traversals
 $\tau$
and
 $\tau '$
at vertices
 $v$
and
 $v'$
, the intersection of
 $V=({{U}}_{{{v}}}\setminus \{v\})\cup \{\tau \}$
and
 $V'=({{U}}_{{{v'}}}\setminus \{v'\})\cup \{\tau '\}$
is nonempty if
 $v=v'$
. So the partial orders of
 $V$
and
 $V'$
coincide because they are induced by
 ${{\sqsubseteq }}_v$
and
 ${{\sqsubseteq }}_{{{v'}}}$
. The rest of the proof follows the one of Lem. 5.10.
Definition 5.20.
The étale local order on
 $\|{G}\|$
is the collection described in Lem. 5.19
; we denote it by
 ${\mathcal E}_{{G}}$
. The underlying topology of
 ${\mathcal E}_{{G}}$
is called the étale topology on
 $\|{G}\|$
; it is generated by the subsets
 $\{a\} \times ]{{t-\varepsilon }},{{t+\varepsilon }}[$
and
 $({{S}}_{{{v}}}\setminus \{v\})\cup \{\tau \}$
with
 $a\in {{G}}^{{({1})}}$
,
 $0\lt \varepsilon \lt \min \{t,\ell (a)-t\}$
,
 $\tau$
a traversal at
 $v\in {{G}}^{{({0})}}$
, and
 ${{S}}_{{{v}}}$
a star centered at
 $v$
(Def. 2.7). The blowup
 ${\beta }_G$
induces a local dihomeomorphism
 ${{e}}_{{{G}}}:{\mathcal E}_{{G}}\to \mathcal{X}_{{G}}$
, which is not Euclidean (Def. 5.6).
Remark 5.21.
The relation between local homeomorphisms and sheaves is explained in (Mac Lane and Moerdijk Reference Mac Lane and Moerdijk1994
, Thm. 2, p. 89). A section of the local homeomorphism
 $\textit {Sp}({{e}}_{{{G}}})$
on an open subset
 $U$
of
 $\textit {Sp}(\mathcal{X}_{{G}})$
is a continuous map
 $s:U\to \textit {Sp}({\mathcal E}_{{G}})$
such that
 ${{{\textit {Sp}({{e}}_{{{G}}})}|}}_{{{{U}}}}\circ s={{id}}_U$
; the map
 $s$
is entirely determined by
 $U$
and a function
 $\phi$
, which “chooses” a traversal at
 $v$
for every vertex
 $v\in U$
(if
 $U$
contains no vertex, then
 $\phi$
is the empty map
 $\emptyset \to \emptyset$
). The sheaf
 $F$
associated with
 ${{e}}_{{{G}}}$
assigns the set of sections of
 ${{e}}_{{{G}}}$
on
 $U$
to every open subset
 $U$
of
 $\textit {Sp}(\mathcal{X}_{{G}})$
, that is
 \begin{equation*} F(U) = \prod _{v\in U\cap {{G}}^{{({0})}}}\{\tau \text{ traversal of } G \text{ at }v\}. \end{equation*}
If we equip the underlying set of
 $G$
with the topology generated by the sets
 $\{a\}$
for
 $a$
arrow of
 $G$
, and
 $\{v\}\cup {{\textrm {src}}}^{{-1}}\{v\}\cup {{\textrm {tgt}}}^{{-1}}\{v\}$
for
 $v$
vertex of
 $G$
(which is an Alexandrov discrete topology (Arenas (Reference Arenas1999))), then
 ${{\pi }}_G:|{G}|\to G$
(Def. 2.6) induces an open continuous map. One defines a sheaf
 $\tilde F$
on the Alexandrov discrete space
 $G$
by setting
 \begin{equation*} \tilde F(A) = \prod _{v\in A\cap {{G}}^{{({0})}}}\{\tau \text{ traversal of } G \text{ at } v\} \end{equation*}
for every open subset
 $A$
of
 $G$
, so we have
 $F(U)=\tilde F({{\pi }}_G(U))$
for every open subset
 $U$
of
 $\textit {Sp}(\mathcal{X}_{{G}})$
.
Remark 5.22.
Denote
 $\mathbf{H}\subseteq \mathbf{Top}$
(p. 24) the full subcategory of Hausdorff spaces. Denote by
 $H:\mathbf{Top}\to \mathbf{H}$
and
 $h:{id}_{\mathbf{Top}}\to IH$
the left adjoint to the inclusion functor
 $I:\mathbf{H}\hookrightarrow \mathbf{Top}$
and its unit. Given a topological space
 $X$
, the Hausdorff space
 $H(X)$
is the quotient of
 $X$
by the smallest equivalence relation
 $\sim$
such that
 $\{(x,y)\in X \times X\mid x\sim y\}$
is closed in
 $X \times X$
, and
 ${{h}}_{{{X}}}$
is the associated quotient map; the latter should be understood as “the best Hausdorff approximation under
 $X$
.” Assume that
 $X$
is the underlying topological space of
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
(resp.
 ${\mathcal E}_{{G}}$
). By Def. 5.15 (resp. 5.20), for all
 $x$
,
 $x'\in X$
with
 $x\ne x'$
, we have
 $x\sim x'$
if, and only if,
 $x$
and
 $x'$
are traversals at the same vertex of
 $G$
. Hence the corestriction of
 ${\beta }_G$
to its image (Rem. 2.16) is the quotient map related to
 $\sim$
, that is, the underlying map of
 ${{h}}_{{{X}}}$
(see Fig.
3
).
5.3 The lifting properties of blowups
5.3.1 Lifting directed paths
Every directed path on the image of
 ${\beta }_G$
can be lifted along it (Thm. 5.29). Nevertheless, such liftings may not be unique when the starting or the finishing point is a vertex. We begin with a simple yet useful observation:
Remark 5.23.
Given a vertex
 $v$
, we have
 $x\:{{\sqsubseteq }}_vv$
or
 $v\:{{\sqsubseteq }}_v\:x$
for every
 $x\in {{U}}_{{{v}}}$
(Def. 5.8). Let
 $C$
be a chain of
 ${{U}}_{{{v}}}$
containing at least two elements. If
 $v$
is an upper bound of
 $C$
, then we have a unique arrow
 $a$
of
 $G$
such that
 $C\setminus \{v\}\subseteq \{a\} \times {{J}}_{{{a}}}$
(Def. 5.8). Moreover
 $\textrm {tgt}\; a=v$
. Similarly, if
 $v$
is a lower bound of
 $C$
, then we have a unique arrow
 $b$
of
 $G$
such that
 $C\setminus \{v\}\subseteq \{b\} \times {{I}}_{{{b}}}$
(Def. 5.8). Moreover,
 $\textrm {src}\; b=v$
. If
 $v$
is neither a lower nor an upper bound of
 $C$
, then
 $v$
is both an upper bound of
 $\downarrow v\cap C$
, and a lower bound of
 $\uparrow v\cap C$
. Therefore, we have a unique traversal
 $(a,b)$
of
 $G$
at
 $v$
such that
 $C$
is entirely contained in the image of
 ${{\xi }}_{{{ab}}}$
(Def. 5.8 (
10
)). In addition, if
 $C$
is unbounded and connected (as a subset of
 ${{U}}_{{{v}}}$
which carries a topology), then it is isomorphic to the pospace
 $\mathbb{R}$
.
Given a path
 $\gamma$
and
 $t\in \textit {dom}\:\gamma$
, we say that
 $\gamma$
is constant before (resp. after)
 $t$
when
 $\gamma (s)=\gamma (t)$
for every
 $s\in \textit {dom}\:(\gamma )$
such that
 $s\leqslant t$
(resp.
 $t\leqslant s$
).
Lemma 5.24.
Let
 $\gamma$
be a directed path on
 $\mathcal{X}_{{G}}$
(Def. 5.7 and 5.11) and
 $t\in \textit {dom}\:\gamma$
such that
 $\gamma (t)$
is a vertex
 $v$
. Suppose that
 $[{{t'}},{{{{t}}{''}}}]$
is the connected component of
 ${{\gamma }}^{{-1}}\{v\}$
containing
 $t$
. If
 $\gamma$
is not constant before
 $t$
(i.e.
 $t'$
is not the least element of
 $\textit {dom}\:\gamma$
), then we have a unique arrow
 $a$
such that for every
 $\varepsilon \in \:]{{0}},{{\ell (a)}}[$
there exists
 $s\in \textit {dom}\:\gamma$
such that
 $s\lt t'$
and
 $ \gamma [{{s}},{{t}}]\setminus \{v\} \subseteq \{a\} \times ]{{\ell (a)-\varepsilon }},{{\ell (a)}}[$
. Moreover,
 $\textrm {tgt}\; a=v$
. Similarly, if
 $\gamma$
is not constant after
 $t$
(i.e.
 ${{t}}{''}$
is not the greatest element of
 $\textit {dom}\:\gamma$
), then we have a unique arrow
 $b$
such that for every
 $\varepsilon \in \:]{{0}},{{\ell (b)}}[$
there exists
 $s\in \textit {dom}\:\gamma$
such that
 ${{t}}{''}\lt s$
and
 $ \gamma [{{t}},{{s}}]\setminus \{v\} \subseteq \{b\} \times ]{{0}},{{\varepsilon }}[$
. Moreover,
 $\textrm {src}\; b=v$
.
Proof.
We have an open interval
 $I'$
containing
 $t'$
such that
 $\gamma$
induces a pospace morphism from
 $I'$
to
 ${{U}}_{{{v}}}$
because
 $\gamma$
is a local order morphism. Let
 $I=\{s\in I'\mid s\leqslant t\}$
, so
 $v$
is an upper bound of the chain
 $\gamma (I)$
of
 ${{U}}_{{{v}}}$
. We readily deduce from the definition of
 $t'$
that
 $\gamma (I)$
is not reduced to
 $\{v\}$
, so Rem. 5.23 applies and we have a unique arrow
 $a$
such that
 $\gamma (I)\setminus \{v\}\subseteq \{a\} \times ]{{0}},{{\ell (a)}}[$
, moreover,
 $\textrm {tgt}\; a=v$
. For
 $\varepsilon \in \:]{{0}},{{\ell (a)/2}}[$
, the star
 $S(v,\varepsilon )$
(Def. 2.7) is an open subset of
 ${{U}}_{{{v}}}$
(Rem. 2.9). Since
 $\gamma$
is continuous, we have a neighborhood
 $J$
of
 $t'$
(with
 $J\subseteq I'$
) such that
 $\gamma (J)\subseteq S(v,\varepsilon )$
. Given
 $s\in I\cap J$
such that
 $s\lt t'$
(which exists because
 $t'\not =\min (\textit {dom}\:(\gamma ))$
), we have
 $\gamma [{{s}},{{t'}}[\:\subseteq \{a\} \times ]{{\ell (a)-\varepsilon }},{{\ell (a)}}[$
. The case where
 $\gamma$
is not constant after
 $t$
is deduced from the previous one by reversing the local order, or by a direct similar proof.
Definition 5.25.
The arrows
 $a$
and
 $b$
given by Lem. 5.24 are referred to as the last arrow visited before
 $t$
, and the first arrow visited after
 $t$
(by
 $\gamma$
). If
 $\textit {dom}\:\gamma =[{{{{t}}_{{{0}}}}},{{{{t}}_{{{1}}}}}]$
, then the first arrow visited by
 $\gamma$
is the first one it visits after
 ${{t}}_{{{0}}}$
. Similarly, the last arrow visited by
 $\gamma$
is the last one it visits before
 ${{t}}_{{{1}}}$
.
If
 $\gamma (t)$
is a vertex, then the traversal
 $(a,b)$
at
 $\gamma (t)$
is said to be compatible with
 $\gamma$
at
 $t$
when the following are satisfied: i) if the last arrow visited before
 $t$
exists, then it is
 $a$
; and ii) if the first arrow visited after
 $t$
exists, then it is
 $b$
.
Remark 5.26.
If
 $\gamma$
is a constant path standing on a vertex
 $v$
, then any traversal at
 $v$
is compatible with
 $\gamma$
at every
 $t\in \textit {dom}\:\gamma$
. If
 $\gamma$
is not constant and starts on a vertex at
 ${{t}}_{{{0}}}$
, then any traversal
 $(a,b)$
such that
 $b$
is the first arrow visited by
 $\gamma$
is compatible at
 ${{t}}_{{{0}}}$
. Dually, if
 $\gamma$
finishes on a vertex at
 ${{t}}_{{{1}}}$
, then any traversal
 $(a,b)$
such that
 $a$
is the last arrow visited by
 $\gamma$
is compatible at
 ${{t}}_{{{1}}}$
.
Lemma 5.27.
Suppose that
 $\gamma (t)$
is a vertex
 $v$
with
 $\gamma$
a directed path on
 $\mathcal{X}_{{G}}$
. For any traversal
 $(a,b)$
compatible with
 $\gamma$
at
 $t$
, and any
 $\varepsilon \in \:]{{0}},{{R}}[$
, there exists an interval
 $I$
open in
 $\textit {dom}\:\gamma$
, containing
 $t$
, and such that
 $\gamma$
induces a pospace morphism
 \begin{equation*} \tilde \gamma \quad :\quad I \quad \to \quad \{{a}\} \times ]{{\ell ({a})-}},{{\ell ({a})}}[\varepsilon \:\:\cup \:\:\{v\}\:\cup \:\{{b}\} \times ]{{0}},[\varepsilon \end{equation*}
whose codomain is an ordered subspace of
 $({{U}}_{{{v}}},{{\sqsubseteq }}_v)$
(Def. 5.8). Moreover, if
 $\gamma$
is not constant before (resp. after)
 $t$
, then
 $\tilde \gamma$
visits
 $\{a\} \times ]{{\ell (a)-\varepsilon }},{{\ell (a)}}[$
(resp.
 $\{b\} \times ]{{0}},{{\varepsilon }}[$
).
Proof.
Let
 $t'$
be the least element of the connected component of
 ${{\gamma }}^{{-1}}\{v\}$
containing
 $t$
. Note that
 $\gamma [{{t'}},{{t}}]=\{v\}$
. If
 $\gamma$
is constant before
 $t$
, then
 $t'$
is the least element of
 $\textit {dom}\:\gamma$
. In that case, we can suppose that
 $t'$
is also the least element of
 $I$
. Otherwise,
 $a$
is the last arrow visited by
 $\gamma$
before
 $t$
(Def. 5.25). By Lem. 5.24, we have
 $s\lt t'$
such that
 $\gamma (]{{s}},{{t'}}])\setminus \{v\}\subseteq \{a\} \times ]{{\ell (a)-\varepsilon }},{{\ell (a)}}[$
. By definition of a local order morphism (Def. 5.6), the map
 $\gamma$
induces a pospace morphism from
 $]{{s}},{{t}}]$
to
 $\{a\} \times ]{{\ell (a)-\varepsilon }},{{\ell (a)}}[\:\cup \:\{v\}$
for
 $s$
sufficiently close to
 $t$
. From the definition of
 $t'$
, we deduce that
 $\gamma (]{{s}},{{t'}}])$
is not reduced to
 $\{v\}$
, therefore, it meets
 $\{a\} \times ]{{\ell (a)-\varepsilon }},{{\ell (a)}}[$
. Whether
 $\gamma$
is constant before
 $t$
or not, we found an interval
 ${{I}}_{{{0}}}$
whose greatest element is
 $t$
, that is not reduced to a single element unless
 $t$
is the least element of
 $\textit {dom}\:\gamma$
, and such that
 $\gamma$
induces a pospace morphism from
 ${{I}}_{{{0}}}$
to
 $\{a\} \times ]{{\ell (a)-\varepsilon }},{{\ell (a)}}[\:\cup \:\{v\}$
. By similar arguments, we obtain an interval
 ${{I}}_{{{1}}}$
whose least element is
 $t$
, that is not reduced to a single element unless
 $t$
is the greatest element of
 $\textit {dom}\:\gamma$
, and such that
 $\gamma$
induces a pospace morphism from
 ${{I}}_{{{1}}}$
to
 $\{v\}\cup \{b\} \times ]{{\ell (b)-\varepsilon }},{{\ell (b)}}[$
. The interval
 $I={{I}}_{{{0}}}\cup {{I}}_{{{1}}}$
matches the requirements.
Proposition 5.28.
Let
 $\gamma$
be a directed path on
 $\mathcal{X}_{{G}}$
. Given a set map
 $\delta$
from
 $\textit {dom}\:\gamma$
to
 $\|{G}\|$
(Def. 2.15), the following are equivalent:
-
(1) The map
$\delta$
is a directed path and satisfies
${\beta }_G\circ \delta =\gamma$
. -
(2) The map
$\delta$
is continuous and satisfies
${\beta }_G\circ \delta =\gamma$
. -
(3) For every
$t\in \textit {dom}\:\gamma$
, if
$\gamma (t)$
is not a vertex, then
$\delta (t)=\gamma (t)$
, otherwise
$\delta (t)$
is a traversal compatible with
$\gamma$
at
$t$
(Def. 5.25).


Proof.
The first point implies the second one because a directed path is (in particular) a local order morphism (Def. 5.7), and every such morphism is continuous (Def. 5.6). Assume the second point is satisfied. Since
 ${\beta }_G\circ \delta =\gamma$
, we have
 $\gamma (t)=\delta (t)$
each time
 $\gamma (t)$
is not a vertex (Def. 2.15). For the same reason, if
 $\gamma (t)$
is a vertex
 $v$
, then
 $\delta (t)$
is a traversal
 $(a,b)$
at
 $v$
. Assume we are in the latter case. Since
 $\delta$
is continuous, and according to the topology of the local order
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
(Rem. 5.16), we have an open interval
 $I$
containing
 $t$
and satisfying
 \begin{equation*} \delta (I) \quad \subseteq \quad (\{a\} \times ]{{\ell (a)-\varepsilon }},{{\ell (a)}}[) \:\cup \: \{(a,b)\} \:\cup \: (\{b\} \times ]{{0}},{{\varepsilon }}[) . \end{equation*}
If
 $\gamma$
is not constant before
 $t$
, then let
 $a'$
be the last arrow visited by
 $\gamma$
before
 $t$
(Lem. 5.24). We have
 $s\lt t$
such that
 $\gamma [{{s}},{{t}}]\setminus \{v\}$
is nonempty and included in
 $\{a'\} \times ]{{\ell (a')-\varepsilon }},{{\ell (a')}}[$
. Since
 $\gamma (s)=\delta (s)$
when
 $\gamma (s)$
is not a vertex, we have
 $a=a'$
. Similarly, if
 $\gamma$
is not constant after
 $t$
, then
 $b$
is the first arrow visited by
 $\gamma$
after
 $t$
. Hence
 $(a,b)$
is compatible with
 $\gamma$
at
 $t$
.
Assume the third point is satisfied. One readily deduces that
 ${\beta }_G\circ \delta =\gamma$
from Def. 2.15 and 5.25. It remains to check that
 $\delta$
is a local order morphism. The mappings
 $\gamma$
and
 $\delta$
agree on
 ${{\delta }}^{{-1}}(\|{G}\|\setminus {{G}}^{{({0})}})$
because
 ${\beta }_G$
leaves unchanged any point of
 $\|{G}\|$
that is not a traversal (Def. 2.15). Let
 $t$
be an element of
 $\textit {dom}\:\gamma$
.
If
 $\gamma (t)$
is not a vertex, then
 $\gamma (t)$
belongs to
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
for a unique arrow
 $a$
. Since
 $\gamma$
is a local order morphism, we have an open interval
 $I$
containing
 $t$
such that the restriction of
 $\gamma$
to
 $I$
induces a pospace morphism from
 $I$
to
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
. Hence the restriction of
 $\delta$
to
 $I$
coincides with the restriction of
 $\gamma$
to
 $I$
; therefore, it is a pospace morphism (the standard pospace
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
belongs to both
 $\mathcal{X}_{{G}}$
and
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
).
If
 $\gamma (t)$
is a vertex
 $v$
, then
 $\delta (t)$
is a traversal
 $(a,b)$
compatible with
 $\gamma$
at
 $t$
(we have supposed that the third point is satisfied). Let
 $\varepsilon \gt 0$
be small enough so that we can apply Lem. 5.27 (with the traversal
 $(a,b)$
) to obtain the pospace morphism
 \begin{equation*} \tilde \gamma \quad :\quad I \quad \to \quad \{{a}\} \times ]{{\ell ({a})-}},{{\ell ({a})}}[\varepsilon \:\:\cup \:\:\{v\}\:\cup \:\{{b}\} \times ]{{0}},[\varepsilon \end{equation*}
induced by
 $\gamma$
with
 $I$
an open interval of
 $\textit {dom}\:\gamma$
containing
 $t$
. We denote by
 ${{\tilde \beta }}_G$
the isomorphism of pospaces induced by the restriction of
 ${\beta }_G$
to
 $\{{a}\} \times ]{{\ell ({a})-}},{{\ell ({a})}}[\varepsilon \:\cup \:\{(a,b)\}\cup \{{b}\} \times ]{{0}},[\varepsilon$
(Rem. 5.16). Then
 ${{{{\tilde \beta }}_G}}^{{-1}}\circ \tilde \gamma$
is a local order morphism defined on
 $I$
satisfying
 ${\beta }_G\circ {{{{\tilde \beta }}_G}}^{{-1}}\circ \tilde \gamma =\tilde \gamma$
. The only vertex that
 $\tilde \gamma$
reaches is
 $v$
, and the maps
 $\delta$
and
 ${{{{\tilde \beta }}_G}}^{{-1}}\circ \tilde \gamma$
agree on
 $\{s\in I\mid \gamma (s)\not =v\}$
. If
 $\tilde \gamma (s)=v$
, then
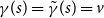 $\gamma (s)=\tilde \gamma (s)=v$
and
 ${{{{\tilde \beta }}_{{{G}}}}}^{{-1}}(v)=(a,b)=\delta (s)$
. Hence
 $\delta$
and
 ${{{{\tilde \beta }}_G}}^{{-1}}\circ \tilde \gamma$
agree on
 $I$
.
Theorem 5.29.
Every directed path
 $\gamma$
on the image of
 ${{\beta }}_{{{{G_{1}}}}} \times \cdots \times {{\beta }}_{{{{G_{n}}}}}$
(seen as a sub-local order of
 $\mathcal{X}_{{G_{1}}} \times \cdots \times \mathcal{X}_{{G_{n}}}$
) admits a lifting (i.e. a directed path
 $\delta$
on the local order
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_{1}}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_{n}}}$
such that
 $({{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_n}}})\circ \delta =\gamma$
).
Proof.
Let
 $t\in \textit {dom}\: \gamma$
. If
 $\gamma (t)$
is not a vertex, put
 $\delta (t)=\gamma (t)$
. Otherwise, there is at least one traversal
 $(a,b)$
at
 $\gamma (t)$
(Def. 2.15). If
 $\gamma$
is not constant before
 $t$
, then we can suppose that
 $a$
is the last arrow visited by
 $\gamma$
before
 $t$
(Def. 5.25). Similarly, if
 $\gamma$
is not constant after
 $t$
, then we can suppose that
 $b$
is the first arrow visited by
 $\gamma$
after
 $t$
. Put
 $\delta (t)=(a,b)$
. The map
 $\delta$
is a lifting of
 $\gamma$
by the third point of Prop. 5.28. The lifting of
 ${{\gamma }}_{1}{ \times }\cdots { \times }{{\gamma }}_{n}$
is obtained by applying the above reasoning to
 ${{\gamma }}_i$
for every
 $i\in \{{1},\ldots ,{n}\}$
.
5.3.2 Universal lifting property
Let
 $X\in \mathcal{X}_{{G}}$
and let
 $x:{\mathbb{R}}\to X$
be a continuous map whose image does not contain any vertex of
 $G$
(the underlying set of
 $\mathcal{X}_{{G}}$
is
 $|{G}|$
, see Def. 2.6). The map
 $x$
thus takes its values in the space
 $|{G}|\setminus {{G}}^{{({0})}}$
, whose connected components are the segments
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
. Consequently, there is a unique arrow
 $a$
such that
 $\textit {img}\:(x)\subseteq \textit {dom}\:({{\phi }}_a)$
, see Def. 3.1. Also, the blowup
 ${\beta }_G$
induces the identity on
 $|{G}|\setminus {{G}}^{{({0})}}$
(Def. 2.15); therefore, we have a unique continuous map
 $\tilde x:{\mathbb{R}}\to \{a\} \times ]{{0}},{{\ell (a)}}[$
such that
 $x(t)={\beta }_G(\tilde x(t))$
for all
 $t\in {\mathbb{R}}$
. If
 $x$
is a pospace embedding, then so is
 $\tilde x$
, and its image is an open subset of
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
. Extending the codomain of
 $\tilde x$
to the whole domain of
 ${\beta }_G$
, we obtain an embedding
 $y$
such that
 $x={\beta }_G\circ y$
and
 $\textit {img}\:(y)$
is open. The next result deals with the case where the image of
 $x$
contains a vertex; we need to introduce (and recall) some notations:
Given a traversal
 $(a,b)$
at
 $v$
, we denote by
 ${{\iota }}_{{{ab}}}$
and
 ${{{{\beta }}^{{({v})}}}}_{G}$
the open embedding of ordered spaces
 $\textit {dom}\:({{\phi }}_{{{ab}}}) \hookrightarrow ({{{\beta }_G}}^{{-1}}{{U}}_{{{v}}},{{\leqslant }}_v)$
and the local embedding of
 $\{({{{\beta }_G}}^{{-1}}{{U}}_{{{v}}},{{\leqslant }}_v)\}$
into
 $\{({{U}}_{{{v}}},{{\sqsubseteq }}_v)\}$
induced by
 ${\beta }_G$
(Rem. 5.18). The composite
 ${{{{\beta }}^{{({v})}}}}_G \circ {{\iota }}_{{{ab}}}$
is the pospace embedding of
 $\textit {dom}\:({{\phi }}_{{{ab}}})$
into
 ${{U}}_{{{v}}}$
induced by
 ${\beta }_G$
(Rem. 5.16). The pospace embedding
 ${{\xi }}_{{{ab}}}$
is described in Def. 5.8 (10).
Proposition 5.30.
For every
 ${{U}}_{{{v}}}\in \mathcal{X}_{{G}}$
(with
 $v$
a vertex of
 $G$
) and every pospace embedding
 $x:{\mathbb{R}}\to {{U}}_{{{v}}}$
with
 $v\in \textit {img}\:(x)$
, there is a unique traversal
 $(a,b)$
at
 $v$
such that
 $\textit {img}\:(x)\subseteq \textit {img}\:({{\xi }}_{{{ab}}})$
. The map
 \begin{equation} y\::\: t\in {\mathbb{R}} \quad \mapsto \quad \left \{ \begin{array}{ll} (a,b) & \text{if}\ x(t)=v \\[2mm] \phantom {(}x(t) & \text{if}\ x(t)\not =v \end{array} \right . \quad \in \quad \textit {dom}\:({{\phi }}_{{{ab}}}) \end{equation}
is the only set map
 $f$
from
 $\mathbb{R}$
to
 $\textit {dom}\:({{\phi }}_{{{ab}}})$
such that
 $x={{{{\beta }}^{{({v})}}}}_G \circ {{\iota }}_{{{ab}}} \circ f$
. Moreover, the open embedding of ordered spaces
 ${{\iota }}_{{{ab}}}\circ y$
is the only continuous map
 $\tilde x$
from
 $\mathbb{R}$
to
 ${{{\beta }_G}}^{{-1}}{{U}}_{{{v}}}$
satisfying
 $x={{{{\beta }}^{{({v})}}}}_G\circ \tilde x$
.
Proof.
The map
 $x$
induces a pospace isomorphism on its image; therefore,
 $\textit {img}\:(x)$
is an unbounded connected chain of
 ${{U}}_{{{v}}}$
. So we have a unique traversal
 $(a,b)$
at
 $v$
such that
 $\textit {img}\:(x)\:\subseteq \:\textit {img}\:({{\xi }}_{{{ab}}})$
(Rem. 5.23). The map
 $y$
readily satisfies the equality
 $x={{{{\beta }}^{{({v})}}}}_G \circ {{\iota }}_{{{ab}}} \circ y$
; it is the only one because
 ${{{{\beta }}^{{({v})}}}}_G \circ {{\iota }}_{{{ab}}} ={{\xi }}_{{{{ab}}}}\circ {{\phi }}_{{{{ab}}}}$
and both
 ${{\xi }}_{{{ab}}}$
and
 ${{\phi }}_{{{ab}}}$
(Def. 3.1 and 5.8 (10)) are one-to-one.
Denote by
 $t$
the only element of
 $\mathbb{R}$
such that
 $x(t)=v$
. By definition of
 ${{{{\beta }}^{{({v})}}}}_G$
(Def. 2.15 and Rem. 5.16), we have
 $\tilde x(s)=x(s)$
for every
 $s\in {\mathbb{R}}\setminus \{t\}$
, and
 $t$
is the only element of
 $\mathbb{R}$
such that
 $\tilde x(t)$
is a traversal
 $(a',b')$
. We deduce that the inverse image of
 $\textit {dom}\:({{\phi }}_{{{a'b'}}})$
under
 $\tilde x$
contains its greatest lower bound (resp. its least upper bound) if
 $a'\not =a$
(resp.
 $b'\not =b$
). Since
 $\tilde x$
is continuous and
 $\textit {dom}\:({{\phi }}_{{{a'b'}}})$
is open in
 ${{{\beta }_G}}^{{-1}}({{U}}_{{{v}}})$
(Rem. 5.18), we have
 $a=a'$
and
 $b=b'$
. We conclude that
 $y$
is the underlying set map of
 $\tilde x$
. The map
 ${{\iota }}_{{{ab}}} \circ y$
is an open embedding of ordered spaces as a composite of such maps (the map
 $y$
is even a dihomeomorphism).
Lemma 5.31.
If
 $\theta :{\mathbb{R}}^n\to {{X}}_{1}{ \times }\cdots { \times }{{X}}_{n}$
is a pospace embedding with
 ${{X}}_{{{k}}}\in \mathcal{X}_{{G_{k}}}$
for every
 $k\in \{{1},\ldots ,{n}\}$
, then
 $\textit {img}\:(\theta )={{C}}_{{{1}}} \times \cdots \times {{C}}_{{{n}}}$
with each
 ${{C}}_{{{k}}}$
an unbounded connected chain of
 ${{X}}_{{{k}}}$
.
Proof.
Write
 ${\theta }_{{\theta } }k={{\text{pr}}}_{{{k}}}\circ \theta$
for the composite of
 $\theta$
followed by the
 $k^{th}$
projection. Assume that
 ${{X}}_{{{k}}}={{U}}_{{{v}}}$
(Def. 5.8 (9)) for some
 $k$
and some vertex
 $v$
of
 ${{G}}_{{{k}}}$
. Any element
 $x\in {{U}}_{{{v}}}$
with
 $x\not =v$
is either smaller or greater than
 $v$
(Rem. 5.23). Moreover, given two elements of
 ${{U}}_{{{v}}}$
that are strictly smaller (resp. greater) than
 $v$
the following are equivalent:
-
– they are comparable in
${{U}}_{{{v}}}$
(i.e. one of them is smaller than the other), -
– they have a lower bound (resp. an upper bound) in
${{U}}_{{{v}}}$
, and -
– they belong to
$\{a\} \times ]{{\tfrac 12\ell (a)}},{{\ell (a)}}[$
for some arrow
$a$
of
${{G}}_{{{k}}}$
such that
$\textrm {tgt}\; a=v$
(resp.
$\{b\} \times ]{{0}},{{\tfrac 12\ell (b)}}[$
for some arrow
$b$
of
${{G}}_{{{k}}}$
such that
$\textrm {src}\; b=v$
).


Given
 $t$
and
 $t'$
in
 ${\mathbb{R}}^n$
, we have
 ${{\theta }}_k(t\wedge t')\leqslant {{\theta }}_k(t)$
,
 ${{\theta }}_k(t')\leqslant {{\theta }}_k(t\vee t')$
because
 $\theta$
and the projections are order preserving. It follows that either
-
–
${{{\theta }}_k}(t)$
and
${{{\theta }}_k}(t')$
belong to
$\{{{a}}_{{{k}}}\} \times ]{{0}},{{\ell ({{a}}_{{{k}}})}}[$
for a unique arrow
${{a}}_{{{k}}}$
of
${{G}}_{{{k}}}$
, or -
– we have
${{{\theta }}_k}(t)\leqslant v\leqslant {{{\theta }}_k}(t')$
or
${{{\theta }}_k}(t')\leqslant v\leqslant {{{\theta }}_k}(t)$
.


We deduce that
 $\textit {img}\:({{\theta }}_k)\subseteq {{J}}_{{{k}}}$
with
 ${{J}}_{{{k}}}$
either of the form
 $\{{{a}}_{{{k}}}\} \times ]{{0}},{{\ell ({{a}}_{{{k}}})}}[$
for some arrow
 ${{a}}_{{{k}}}$
, or
 $\{{{a}}_{{{k}}}\} \times ]{{0}},{{\ell ({{a}}_{{{k}}})}}[\:\cup \:\{v\}\cup \{{{B}}_{{{k}}}\} \times ]{{0}},{{\ell ({{B}}_{{{k}}})}}[$
for some traversal
 $({{a}}_{{{k}}},{{B}}_{{{k}}})$
at
 $v$
. We have a dihomeomorphism
 $\psi :{{J}}_{1}{ \times }\cdots { \times }{{J}}_{n}\cong {\mathbb{R}}^n$
obtained as a product of dihomeomorphisms
 ${{\psi }}_k:{{J}}_{{{k}}}\cong {\mathbb{R}}$
. The corestriction
 $\tilde \theta$
of
 $\theta$
to
 $\textit {img}\:(\theta )$
is a dihomeomorphism. Hence, the composite

is a pospace embedding, so its image is a product of open intervals
 ${{I}}_{1}{ \times }\cdots { \times }{{I}}_{n}$
(Lem. 5.5) and for every
 $k\in \{{1},\ldots ,{n}\}$
, the chain
 ${{C}}_{{{k}}}$
is
 ${{{{\psi }}_k}}^{{-1}}({{I}}_{{{k}}})$
.
Proposition 5.32.
If
 $\theta$
is a pospace embedding as in Lem. 5.31
, then there is a unique permutation
 $\sigma \in \mathfrak S_n$
and a unique tuple of pospace embeddings
 $({{x}}_{{1},\ldots ,{{x}}_{n}})$
with
 ${{x}}_{{{k}}}:{\mathbb{R}}\to {{X}}_{{{k}}}$
for
 $k\in \{{1},\ldots ,{n}\}$
such that
 $\theta =({{x}}_{1}{ \times }\cdots { \times }{{x}}_{n})\circ {{\pi }}_{{{\sigma }}}$
– see Def. 5.1
.
Proof.
From Lem. 5.31, we know that the corestriction of
 $\theta$
to its image is a pospace isomorphism of the form
 $\tilde \theta :{\mathbb{R}}^n\to C_1 \times \cdots \times C_n$
with each
 ${{C}}_{{{k}}}$
a connected unbounded chain of
 ${{X}}_{{{k}}}$
. Then for every
 $k\in \{{1},\ldots ,{n}\}$
, we have a pospace isomorphism
 ${{\psi }}_k:{{C}}_{{{k}}}\cong {\mathbb{R}}$
. Denoting by
 $\psi$
the pospace isomorphism
 ${{\psi }}_{n}\cdots {n}{{\psi }}_{1} \times $
, the composite
 $\psi \circ \tilde \theta$
is a pospace automorphism of
 ${\mathbb{R}}^n$
. From Lem. 5.2 and Rem. 5.3, we deduce that
 $ \psi \circ \tilde \theta = ({{\xi }}_{1}{ \times }\cdots { \times }{{\xi }}_{n}) \circ {{\pi }}_{{{\sigma }}}$
for a unique family
 ${{\xi }}_{{1},\ldots ,{{\xi }}_{n}}$
of automorphisms of the poset
 $\mathbb{R}$
and a unique
 $\sigma \in \mathfrak S_n$
. It follows from Def. 5.1 (7) that
 \begin{equation*}\tilde \theta = \Big (\big (\underbrace {{{{{\psi }}_{{{1}}}}}^{{-1}}\circ {{\xi }}_{{{1}}}}_{{{y}}_{{y}{{1}}}}\big ) \times \cdots \times \big (\underbrace {{{{{\psi }}_n}}^{{-1}}\circ {{\xi }}_n}_{{{y}}_{{y}{{n}}}}\big )\Big )\circ {{\pi }}_{{{\sigma }}}\:.\end{equation*}
We conclude by setting
 ${{x}}_{{{k}}}=({{C}}_{{{k}}}\hookrightarrow {{X}}_{{{k}}})\circ {{y}}_{{y}{{k}}}$
for every
 $k\in \{{1},\ldots ,{n}\}$
. The uniqueness of the decomposition of
 $\theta$
is deduced from the uniqueness of the decomposition of
 $\psi \circ \tilde \theta$
.
Theorem 5.33.
For every Euclidean local embedding of local orders
 $f:\mathcal{M}_{{}}\to \mathcal{X}_{{G_1}} \times \cdots \times \mathcal{X}_{{G_n}}$
of dimension
 $n$
(Def. 5.6), there is a unique continuous map
 $g:\mathcal{M}_{{}}\to \,{\tilde {\mathcal{\!\!X}}}_{{G_1}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_n}}$
such that
 $f=\bar \beta \circ g$
with
 $\bar \beta ={{\beta }}_{{{G_1}}} \times \cdots \times {{\beta }}_{{{G_{n}}}}$
; moreover,
 $g$
is a Euclidean local dihomeomorphism.
Proof.
We say that
 $E\subseteq \mathcal{M}_{{}}$
is admissible when it is dihomeomorphic to
 ${\mathbb{R}}^n$
and there exists
 $X\in \mathcal{X}_{{G_1}} \times \cdots \times \mathcal{X}_{{G_n}}$
(Def. 5.11) such that
 $f(E)\subseteq X$
and the restriction of
 $f$
to
 $E$
with values in
 $X$
, which we denote by
 ${{f}}_{{{E}}}^{{{X}}}$
, is a pospace embedding. We have
 $X={{X}}_{1}{ \times }\cdots { \times }{{X}}_{n}$
with
 ${{X}}_{{{k}}}\in \mathcal{X}_{{G_{k}}}$
for
 $k\in \{{1},\ldots ,{n}\}$
. Given a dihomeomorphism
 ${{\varphi }}_E:E\cong {\mathbb{R}}^n$
, we apply Prop. 5.32 to the embedding
 ${{f}}_{{{E}}}^{{{X}}}\circ {{{{\varphi }}_E}}^{{-1}}$
to obtain
 $ {{f}}_{{{E}}}^{{{X}}} = ({{x}}_{1}{ \times }\cdots { \times }{{x}}_{n})\circ \pi _{\sigma }\circ {{\varphi }}_E$
with
 $\sigma \in \mathfrak S_n$
and
 $x_k:{\mathbb{R}}\to X_k$
a pospace embedding for every
 $k\in \{{1},\ldots ,{n}\}$
. We can suppose that
 $\sigma$
is the identity, even if it means replacing
 ${{\varphi }}_E$
by
 $\pi _{\sigma }\circ {{\varphi }}_E$
; in other words, we can suppose that
 \begin{equation} {{f}}_{{{E}}}^{{{X}}} = ({{x}}_{1}{ \times }\cdots { \times }{{x}}_{n})\circ {{\varphi }}_E. \end{equation}
Let
 $k\in \{{1},\ldots ,{n}\}$
. We prove that there is a unique continuous map
 ${{\tilde x}}_{{{k}}}:{\mathbb{R}}\to {{{{\beta }}_{{{G_k}}}}}^{{-1}}{{X}}_{{{k}}}$
such that
 \begin{equation} {{x}}_{{{k}}} = {{\beta }}_{{{X_k}}}\circ {{\tilde x}}_{{{k}}} \end{equation}
with
 ${{\beta }}_{{{X_k}}}$
denoting the restriction of
 ${{\beta }}_{{{G_k}}}$
to
 ${{{{\beta }}_{{{G_k}}}}}^{{-1}}{{X}}_{{{k}}}$
with values in
 ${{X}}_{{{k}}}$
. If
 ${{X}}_{{{k}}}=\{a\} \times ]{{0}},{{\ell (a)}}[$
, then
 ${{\tilde x}}_{{{k}}}$
is the identity map on
 $\{a\} \times ]{{0}},{{\ell (a)}}[$
. If
 $X_k=({{U}}_{{{v}}},{{\sqsubseteq }}_v)$
, then
 ${{\tilde x}}_{{{k}}}$
is obtained by applying Prop. 5.30 to the pospace embedding
 ${{x}}_{{{k}}}$
. In both cases,
 ${{\tilde x}}_{{{k}}}$
is an open embedding of ordered spaces, so the map
 \begin{equation} {{g}}_{{{E}}}^{{{X}}} = ({{\tilde x}}_{1}{ \times }\cdots { \times }{{\tilde x}}_{n})\circ {{\varphi }}_E \end{equation}
which we call a canonical local lifting of
 $f$
on
 $E$
, is also an open embedding of ordered spaces. As a consequence of (13), (14), and (15), we have
 \begin{equation} {{f}}_{{{E}}}^{{{X}}} = {{\beta }}_X \circ ({{\tilde x}}_{1}{ \times }\cdots { \times }{{\tilde x}}_{n})\circ {{\varphi }}_E = {{\beta }}_X \circ {{g}}_{{{E}}}^{{{X}}}\quad \text{with }{{\beta }}_X={{\beta }}_{{{X_1}}} \times \cdots \times {{\beta }}_{{{X_n}}}. \quad \end{equation}
Given
 $k\in \{{1},\ldots ,{n}\}$
, we postcompose the
 $k^{th}$
projection (
 ${{\text{pr}}}_{{{k}}}$
) on both sides of the equalities (13) and (16); we obtain
 \begin{equation} {{\text{pr}}}_{{{k}}}\circ {{f}}_{{{E}}}^{{{X}}} = {{x}}_{{{k}}}\circ {{\text{pr}}}_{{{k}}}\circ {{\varphi }}_E = {{\beta }}_{{{X_k}}}\circ {{\tilde x}}_{{{k}}}\circ {{\text{pr}}}_{{{k}}}\circ {{\varphi }}_E. \end{equation}
By doing the same to the relation (15), we obtain
 \begin{equation} {{\text{pr}}}_{{{k}}}\circ {{g}}_{{{E}}}^{{{X}}} = {{\tilde x}}_{{{k}}}\circ {{\text{pr}}}_{{{k}}}\circ {{\varphi }}_E. \end{equation}
Given
 $e\in E$
, in order to prove that
 ${{g}}_{{{E}}}^{{{X}}}(e)$
only depends on
 $f$
and
 $e$
, it suffices to prove that so does
 ${{\tilde x}}_{{{k}}}\circ {{\text{pr}}}_{{{k}}}\circ {{\varphi }}_E(e)$
for every
 $k\in \{{1},\ldots ,{n}\}$
. If
 ${{\text{pr}}}_{{{k}}}(f(e))$
is not a vertex, then
 ${{\tilde x}}_{{{k}}}({{\text{pr}}}_{{{k}}}({{\varphi }}_E(e)))={{\text{pr}}}_{{{k}}}(f(e))$
by (17) and Def. 2.15. If
 ${{\text{pr}}}_{{{k}}}(f(e))$
is a vertex, then
 $\tilde x_k({{\text{pr}}}_{{{k}}}({{\varphi }}_E(e)))$
is the unique traversal
 $(a,b)$
of the graph
 ${{G}}_{{{k}}}$
such that
 $\textit {img}\:({{x}}_{{{k}}})\subseteq \textit {img}\:({{\xi }}_{{{ab}}})$
– see Prop. 5.30 which was applied to define
 ${{\tilde x}}_{{{k}}}$
. Since
 ${{\text{pr}}}_{{{k}}}\circ {{\varphi }}_E$
is onto, we deduce from (17) that
 $\textit {img}\:({{x}}_{{{k}}})={{\text{pr}}}_{{{k}}}(f(E))$
. Hence
 ${{\tilde x}}_{{{k}}}({{\text{pr}}}_{{{k}}}({{\varphi }}_E(e)))$
is the only traversal
 $(a,b)$
such that
 ${{\text{pr}}}_{{{k}}}(f(E))\subseteq \textit {img}\:({{\xi }}_{{{ab}}})$
. So far, the traversal
 $(a,b)$
depends on
 $f$
and
 $E$
. Nevertheless, if
 $e\in E'\subseteq E$
with
 $E'$
dihomeomorphic to
 ${\mathbb{R}}^n$
, then we have
 ${{f}}_{{{E'}}}^{{{X}}}$
the restriction of
 $f$
to
 $E'$
with values in
 $X$
, and by the same reasoning as above with
 $E'$
instead of
 $E$
, we prove that we have a unique traversal
 $(a',b')$
such that
 ${{\text{pr}}}_{{{k}}}(f(E'))\subseteq \textit {img}\:({{\xi }}_{{{a'b'}}})$
. Then we have
 $(a',b')=(a,b)$
because
 ${{\text{pr}}}_{{{k}}}(f(E')) \subseteq {{\text{pr}}}_{{{k}}}(f(E)) \subseteq \textit {img}\:({{\xi }}_{{{ab}}})$
. Hence
 ${{g}}_{{{E}}}^{{{X}}}(e)$
only depends on
 $f$
and
 $e$
. In particular, two canonical local liftings
 ${{g}}_{{{E}}}^{{{X}}}$
and
 ${{g}}_{{{E'}}}^{{g}{{X'}}}$
agree on
 $E\cap E'$
. By hypothesis,
 $\mathcal{M}_{{}}$
is covered by its admissible subsets so we can define
 $g:\mathcal{M}_{{}}\to \,{\tilde {\mathcal{\!\!X}}}_{{G_1}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_n}}$
by setting
 $g(p)={{g}}_{{{E}}}^{{{X}}}(p)$
for any canonical local lifting
 ${{g}}_{{{E}}}^{{{X}}}$
of
 $f$
with
 $p\in E$
. We have
 $f=\bar \beta \circ g$
by (16), and
 $g$
is a Euclidean local dihomeomorphism because the maps
 ${{g}}_{{{E}}}^{{{X}}}$
are open embeddings of ordered spaces.
Let
 $h:\mathcal{M}_{{}}\to \,{\tilde {\mathcal{\!\!X}}}_{{G_1}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_n}}$
be a continuous map satisfying
 $\bar \beta \circ h=\bar \beta \circ g$
. Given
 $p\in \mathcal{M}_{{}}$
, we have a canonical local lifting
 ${{g}}_{{{E}}}^{{{X}}}$
with
 $p\in E$
. Since
 $\textit {dom}\:({{\beta }}_X)={{(\bar \beta )}}^{{-1}}X$
, we have
 ${{\beta }}_X\circ {{g}}_{{{E}}}^{{{X}}}={{\beta }}_X\circ {{h}}_{{{E}}}^{{{X}}}$
with
 ${{h}}_{{{E}}}^{{{X}}}$
denoting the restriction of
 $h$
to
 $E$
with values in
 $\textit {dom}\:({{\beta }}_X)$
. From the latter equality and the definition of
 ${{g}}_{{{E}}}^{{{X}}}$
(15), we deduce that
 $ {{\beta }}_{{{X_k}}}\circ {{\tilde x}}_{{{k}}}\circ {{\text{pr}}}_{{{k}}} = {{\beta }}_{{{X_k}}}\circ {{\text{pr}}}_{{{k}}} \circ {{h}}_{{{E}}}^{{{X}}} \circ {{{{\varphi }}_{{{E}}}}}^{{-1}}$
with
 $k\in \{{1},\ldots ,{n}\}$
and
 ${{\text{pr}}}_{{{k}}}$
denoting the
 $k^{th}$
projection. Given any continuous map
 $\gamma :{\mathbb{R}}\to {\mathbb{R}}^n$
such that
 ${{\text{pr}}}_{{{k}}}\circ \gamma ={id}_{\mathbb{R}}$
, we have
 $ {{\beta }}_{{{X_k}}}\circ {{\tilde x}}_{{{k}}} = {{\beta }}_{{{X_k}}}\circ {{\text{pr}}}_{{{k}}} \circ {{h}}_{{{E}}}^{{{X}}} \circ {{{{\varphi }}_{{{E}}}}}^{{-1}}\circ \gamma$
. We deduce from the uniqueness property in Prop. 5.30 that
 $ {{\tilde x}}_{{{k}}} = {{\text{pr}}}_{{{k}}} \circ {{h}}_{{{E}}}^{{{X}}} \circ {{{{\varphi }}_{{{E}}}}}^{{-1}}\circ \gamma$
. We can suppose that
 $\gamma (t)={{\varphi }}_E(p)$
for some
 $t\in {\mathbb{R}}$
so we have
 $ {{\tilde x}}_{{{k}}}(t) = {{\tilde x}}_{{{k}}}\circ {{\text{pr}}}_{{{k}}}\circ {{\varphi }}_E(p) = {{\text{pr}}}_{{{k}}}\circ {{h}}_{{{E}}}^{{{X}}}(p)$
, that is to say
 $ {{\text{pr}}}_{{{k}}}\circ {{g}}_{{{E}}}^{{{X}}}(p) = {{\text{pr}}}_{{{k}}}\circ {{h}}_{{{E}}}^{{{X}}}(p)$
by (18).
The identity map
 ${{id}}_{{{\|{G}\|}}}$
induces a
 $1$
-dimensional Euclidean local embedding of local orders
 ${{\iota }}_G:\,{\tilde {\mathcal{\!\!X}}}_{{G}}\to {\mathcal E}_{{G}}$
, which is not open (Def. 5.6, 5.15, and 5.20). Given a tuple of graphs
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
, we write
 $\bar e$
and
 $\bar \iota$
to denote the products
 ${{e}}_{{{G_1}}} \times \cdots \times {{e}}_{{{G_{n}}}}$
and
 ${{\iota }}_{{{G_1}}} \times \cdots \times {{\iota }}_{{{G_{n}}}}$
. If
 $f:\mathcal{M}_{{}}\to {\mathcal E}_{{G_1}} \times \cdots \times {\mathcal E}_{{G_n}}$
is a Euclidean local embedding of dimension
 $n$
, then so is
 $\bar e\circ f$
, and we have
 $\bar e\circ f=\bar \beta \circ g=\bar e\circ \bar \iota \circ g$
with
 $g$
given by Thm. 5.33; however, in general, we cannot deduce that
 $f=\bar \iota \circ g$
:
Example 5.34.
Consider the graph
 $G$
on the left-hand part of Fig.
3
(p. 10) and let
 $f$
be the directed arc on the étale local order
 ${\mathcal E}_{{G}}$
covering
 $\{a\} \times ]0,1[\:\cup \:\{(a,c)\}\cup \{b\} \times ]0,1[$
, see the right-hand part of Fig.
3
. The map
 $f$
is not even continuous on the underlying topological space of the standard local order
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
. The unique continuous map
 $g$
such that
 $\bar e\circ f=\bar \beta \circ g$
is the directed arc on
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
covering
 $\{a\} \times ]0,1[\:\cup \:\{(a,b)\}\cup \{b\} \times ]0,1[$
; hence
 $f$
and
 $\bar \iota \circ g$
differ in only one point. Such a pathology is possible because the underlying space of
 ${\mathcal E}_{{G}}$
is not Hausdorff.
5.4 Cone fields and local orders
For any manifold
 $M$
, there is an equivalence (in the categorical sense) between the local orders on (the underlying set of)
 $M$
whose elements are locally order convex (p. 21), and the upper semi-continuous cone fields on
 $M$
admitting sections at every point (Lawson, Reference Lawson1989, 2.7). The above statement involves a manifold instead of an atlas, and Lawson (Reference Lawson1989) does not make the topological properties required on
 $M$
explicit. However, this statement is local by nature, and its proof does not require the topology of
 $M$
to be Hausdorff or second countable. If it holds for the atlas
 $\mathcal{A}_{{G_{1}}} \times \cdots \times \mathcal{A}_{{G_{n}}}$
, then the cone field associated to the standard parallelization and the standard local order on
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_{1}}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_{n}}}$
are related by this equivalence (Prop. 5.38 and Thm. 5.41). Except for the latter results, this section is entirely based on (Lawson, Reference Lawson1989, §1 and §2).
A wedge is a topologically closed subset
 $W$
of a finite-dimensional real vector space such that
 $\mathbb{R}_{{+}} W\subseteq W$
and
 $W+W\subseteq W$
. A cone is a wedge
 $C$
such that
 $C\cap -C=\{0\}$
. A cone field on an atlas
 $\mathcal{A}_{{}}$
is a map assigning a cone
 $C(p)$
of the tangent space
 $T_p\mathcal{A}_{{}}$
to every point
 $p$
of
 $\mathcal{A}_{{}}$
, see Figure 5 and Ex. 5.35. A conal atlas is an atlas together with a cone field. If
 $C$
and
 $D$
are cone fields on the atlases
 $\mathcal{A}_{{}}$
and
 $\mathcal{B}_{{}}$
, then the mapping
 $C \times D$
is a cone field on
 $\mathcal{A}_{{}} \times \mathcal{B}_{{}}$
.
A cone field on the plane.

Example 5.35.
Any parallelization
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
(§
A.3
, p. 51) canonically induces a cone field:
 \begin{equation*} C(p) = \big \{{{\lambda }}_{{\lambda }{{1}}}{{f}}_{{{1}}}(p)+\cdots +{{\lambda }}_{{\lambda } }n{{f}}_{{{n}}}(p)\ \big |\ \big \}{{{\lambda }}_{{\lambda } }i\geqslant 0\:\text{ for all } i\in \{{1},\ldots ,{n}\}}. \end{equation*}
Such cone fields are said to be Cartesian. If
 $C$
and
 $D$
are the Cartesian cones induced by the parallelizations
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
and
 $({{g}}_{{1},\ldots ,{{g}}_{m}})$
, then
 $C \times D$
is the Cartesian cone induced by the parallelization
 $({{f}}_{{1},\ldots ,{{f}}_{n}},{{g}}_{{1},\ldots ,{{g}}_{m}})$
.
Definition 5.36.
The standard cone field
 ${{C}}_{{{G}}}$
on
 $\mathcal{A}_{{G}}$
is the Cartesian cone field induced by its standard parallelization (Def. 3.6), that is to say:
 \begin{equation*} {{C}}_{{{G}}}\quad :\quad p\in \|{G}\|\quad \mapsto \quad \big \{(p,t)\ \big |\ t\in \mathbb{R}_{{+}}\big \}\quad \text{ cone of } \:\{p\} \times {\mathbb{R}}.\quad \end{equation*}
5.4.1 Conal preorder
For every curve
 $c$
extending a smooth path
 $\gamma$
(Def. A.7) and every
 $t\in \textit {dom}\:(\gamma )$
, we have the left-hand and the right-hand derivatives of
 $\gamma$
at
 $t$
, namely
 \begin{equation*} \lim _{\phantom {x}x\to t^-}({D{\gamma )}}_{}x = {D{c}}_{{t}} \qquad \text{and}\qquad \lim _{\phantom {x}x\to t^+}({D{\gamma )}}_{}x = {D{c}}_{{t}}; \end{equation*}
which we denote by
 $D\gamma _{{t^-}}$
and
 $D\gamma _{{t^+}}$
. A piecewise smooth path admits derivatives on both sides at every
 $t$
, although there are finitely many
 $t$
’s at which they may not coincide.
A piecewise smooth path
 $\gamma$
is said to be conal on
 $(\mathcal{A}_{{}},C)$
if
 $D\gamma _{{t^+}}\in C(\gamma (t))$
for every
 $t\in \textit {dom}\:(\gamma )$
. Given the points
 $p$
and
 $q$
of an open subset
 $U$
of
 $\mathcal{A}_{{}}$
, we write
 $p\:{{\preccurlyeq }}_U\:q$
when there exists a conal curve on
 $U$
from
 $p$
to
 $q$
. The relation
 ${{\preccurlyeq }}_U$
thus defined is the conal preorder on
 $U$
.
5.4.2 Infinitesimal preorder
A partial curve on an atlas
 $\mathcal{A}_{{}}$
is a map
 $\gamma :D\to |{\mathcal{A}_{{}}}|$
with
 $0\in D\subseteq \mathbb{R}_{{+}}$
and
 $0$
a cluster point of
 $D$
(Munkres, Reference Munkres2000, §17, p. 97). Given
 $X\subseteq |{\mathcal{A}_{{}}}|$
, we say that
 $v\in T_{p}\mathcal{A}_{{}}$
is a subtangent vector of
 $X$
at
 $p$
when there exists a partial curve
 $\gamma :D\to |{\mathcal{A}_{{}}}|$
with
 $\gamma (0)=p$
and
 $\gamma (D\setminus \{0\})\subseteq X$
, and a chart
 $\phi \in \mathcal{A}_{{}}$
such that
 $p\in \textit {dom}\:(\phi )$
and
 \begin{equation*} {{[[{{v}}]]}}_{{{p}}}^{{{\phi }}} = \lim _{0\leftarrow t\in D} \tfrac 1t \big (\phi (\gamma (t)) - \phi (p) \big ). \end{equation*}
Given
 $\psi \in \mathcal{A}_{{}}$
with
 $p\in \textit {dom}\:\psi$
, it suffices to write
 $\psi \circ \gamma =(\psi \circ {{\phi }}^{{-1}})\circ (\phi \circ \gamma )$
and apply the chain rule (i.e. a form of the chain rule adapted to partial curves) to check that the above equality still holds with
 $\psi$
instead of
 $\phi$
.
Assume that the local order
 $\mathcal{X}_{{}}$
and the atlas
 $\mathcal{A}_{{}}$
are based on the same topological space. The infinitesimal preorder of
 $\mathcal{X}_{{}}$
is the map assigning to each point
 $p\in \mathcal{A}_{{}}$
the smallest wedge
 ${{W}}_{{{p}}}$
of
 ${{T}}_{{{p}}}\mathcal{A}_{{}}$
containing all the subtangent vectors of the set
 $\{p\:{{\leqslant }}_U\:u\mid u\in U\}$
at
 $p$
for some
 $(U,\leqslant )\in \mathcal{X}_{{}}$
such that
 $p\in U$
. Because of the coherence condition satisfied by a local order, the wedge
 ${{W}}_{{{p}}}$
does not depend on
 $(U,\leqslant )$
. In the context of this article,
 ${{W}}_{{{p}}}$
is roughly the set of speed vectors
 $\gamma '(t)$
for curves
 $\gamma$
on
 $\mathcal{A}_{{}}$
that are directed on
 $\mathcal{X}_{{}}$
and satisfy
 $\gamma (t)=p$
with
 $t\in \textit {dom}\:(\gamma )$
.
Example 5.37.
Assume that
 $\mathcal{X}_{{}}$
is the local order on the punctured plane (at the origin) whose directed paths are of the form
 $t\in J\mapsto \rho (t)e^{i\theta (t)}\in {\mathbb{R}}^2\setminus \{0\}$
with
 $J$
interval of
 $\mathbb{R}$
, and
 $\rho :J\to \:]{{0}},{{\infty }}[$
,
 $\theta :J\to {\mathbb{R}}$
non decreasing continuous maps. The inifinitesimal preorder of
 $\mathcal{X}_{{}}$
is the one shown in Fig.
5
, that is,
 ${{W}}_{{{(x,y)}}}=\{a(x,y)+b({-}y,x)\mid a,b\in \mathbb{R}_{{+}}\}$
.
The correspondence between conal preorders and infinitesimal preorders (which is the subject of the next paragraph) is dealt with in (Lawson (Reference Lawson1989)) by means of partial curves.
5.4.3 Lawson correspondence
We say that the cone
 $C'$
surrounds the cone
 $C$
when
 $C\setminus \{0\}$
is contained in the interior of
 $C'$
(Hilgert et al., Reference Hilgert, Hofmann and Lawson1989, IV.2.10, p. 304). Given a chart
 $\phi \in \mathcal{A}_{{}}$
and
 $p$
,
 $q\in \textit {dom}\:\phi$
, the composite
 ${{({{[[{{\_}}]]}}_{{{q}}}^{{{\phi }}})}}^{{-1}}\circ {{[[{{\_}}]]}}_{{{p}}}^{{{\phi }}}:{{T}}_{{{p}}}\mathcal{A}_{{}}\to {{T}}_{{{q}}}\mathcal{A}_{{}}$
is a topological vector space isomorphism (Def. A.12), which we denote by
 ${{[[{{\_}}]]}}_{{{pq}}}^{{{\phi }}}$
; its inverse is
 ${{[[{{\_}}]]}}_{{{qp}}}^{{{\phi }}}$
, and
 ${{[[{{\_}}]]}}_{{{pp}}}^{{{\phi }}}$
is the identity map.
A cone field
 $C$
on
 $\mathcal{A}_{{}}$
is said to be upper semi-continuous at
 $p$
when for every chart
 $\phi \in \mathcal{A}_{{}}$
such that
 $p\in \textit {dom}\:(\phi )$
, and every cone
 $C'$
that surrounds
 $C(p)$
, there exists a neighborhood
 $U$
of
 $p$
such that
 $C'$
surrounds
 ${{[[{{C(q)}}]]}}_{{{qp}}}^{{{\phi }}}$
for every
 $q\in U$
. We say that
 $C$
admits sections at
 $p$
when for every
 $v\in C(p)$
, there exists a vector field
 $f$
on
 $\mathcal{A}_{{}}$
such that
 $f(p)=v$
.
An open cover
 $\mathcal{U}$
of the atlas
 $\mathcal{A}_{{}}$
is said to be admissible for a cone field
 $C$
on
 $\mathcal{A}_{{}}$
when for every
 $U\in \mathcal{U}$
the conal preorder
 ${{\preccurlyeq }}_U$
is antisymmetric, the pospace
 $(U,{{\preccurlyeq }}_U)$
is locally order convex (§5.1, p. 21), and the collection
 $\{(U,{{\preccurlyeq }}_U)\mid U\in \mathcal{U}\}$
is a local order. Given an atlas
 $\mathcal{A}_{{}}$
, Lawson’s result (Lawson, Reference Lawson1989, 2.7) states that:
-
(1) For every upper semi-continuous cone field
$C$
on
$\mathcal{A}_{{}}$
admitting sections at every point, there exists an open cover
$\mathcal{U}$
admissible for
$C$
. Moreover, for every open cover
$\mathcal{U}$
admissible for
$C$
, the infinitesimal preorder of
$\{(U,{{\preccurlyeq }}_U)\mid U\in \mathcal{U}\}$
is
$C$
. -
(2) For every local order
$\mathcal{X}_{{}}$
made of locally convex pospaces, the infinitesimal preorder of
$\mathcal{X}_{{}}$
is an upper semi-continous cone field
$C$
on
$\mathcal{A}_{{}}$
admitting sections at every point. Moreover, the local order
$\mathcal{X}_{{}}$
is equivalent (in the sense of §5.2, p. 23) to
$\{(U,{{\preccurlyeq }}_U)\mid U\in \mathcal{U}\}$
for every open cover
$\mathcal{U}$
admissible for
$C$
.


Proposition 5.38.
The standard local order
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
on
 $\|{G}\|$
(Def. 5.15) and the standard cone field
 ${{C}}_{{{G}}}$
on
 $\mathcal{A}_{{G}}$
(Def. 5.36) are deduced from each other along Lawson’s correspondence.
Proof.
The fact that
 ${{C}}_{{{G}}}$
is upper semi-continuous and admits sections at every point is immediate. Denote by
 ${\sqsubseteq }_{\sqsubseteq }{ab}$
the partial order of the pospace
 $\textit {dom}\:({{\phi }}_{{{ab}}})\in \tilde {\mathcal{X}}_{{G}}$
. Denote by
 ${{\preccurlyeq }}_{{{ab}}}$
the conal preorder on
 $\textit {dom}\:({{\phi }}_{{{ab}}})$
induced by
 ${{C}}_{{{G}}}$
. Let
 $p$
,
 $q\in \textit {dom}\:{{{\phi }}_{{{ab}}}}$
. The inequality
 $p\:{{\sqsubseteq }}_{{{ab}}}q$
amounts to
 ${{\phi }}_{ab}p\leqslant {{\phi }}_{ab}q$
in
 $\mathbb{R}$
. The restriction of
 ${{{{\phi }}_{{{ab}}}}}^{{-1}}$
to the segment
 $[{{{{\phi }}_{{{ab}}}p}},{{{{\phi }}_{{{ab}}}q}}]$
is a conal curve on
 $\textit {dom}\:{{{\phi }}_{{{ab}}}}$
, which implies that
 $p\:{{\preccurlyeq }}_{{{ab}}}q$
. The other way round, if
 $p\:{{\preccurlyeq }}_{{{ab}}}q$
, then we have a piecewise smooth conal curve
 $\gamma$
on
 $\textit {dom}\:{{{\phi }}_{{{ab}}}}$
from
 $p$
to
 $q$
. The fact that
 $\gamma$
is conal means that for every
 $t\in \textit {dom}\:(\gamma )$
, we have
 ${D{\gamma }}_{{t}}(1)=r{{C}}_{{{G}}}(p)$
with
 $r\gt 0$
, and therefore the map
 ${{{{\phi }}_{{{ab}}}}}^{{-1}}\circ \gamma$
is a piecewise derivative map between intervals of
 $\mathbb{R}$
whose derivative is non-negative; it is thus non-decreasing. The map
 ${{\phi }}_{{{ab}}}$
(Def. 3.1) is a dihomeomorphism (Def. 5.15 and its preamble), hence
 $\gamma$
is a pospace morphism; we deduce that
 $p\:{{\sqsubseteq }}_{{{ab}}}q$
. Given
 ${{\phi }}_a\in \,{\tilde {\mathcal{\!\!X}}}_{{G}}$
the same reasoning holds for the partial order
 ${{\sqsubseteq }}_a$
on
 $\textit {dom}\:({{\phi }}_a)$
, and
 ${{\preccurlyeq }}_a$
the conal preorder on
 $\textit {dom}\:({{\phi }}_a)$
induced by
 ${{C}}_{{{G}}}$
. So we have proven that
 ${{\sqsubseteq }}_{{{ab}}}$
(resp.
 ${{\sqsubseteq }}_a$
) is the conal preorder on
 $\textit {dom}\:({{\phi }}_{{{ab}}})$
(resp.
 $\textit {dom}\:({{\phi }}_a)$
) induced by
 ${{C}}_{{{G}}}$
. It follows that the collection
 \begin{equation*} \mathcal{U} = \big \{\textit {dom}\:({{\phi }}_a)\ \big |\ \big \}{a \text{ arrow of } G} \:\cup \: \big \{\textit {dom}\:({{\phi }}_{{{ab}}})\ \big |\ \big \}{(a,b)\ \text{traversal of } G} \end{equation*}
is admissible for
 ${{C}}_{{{G}}}$
, and that the local order
 $\{(U,{{\preccurlyeq }}_U)\mid U\in \mathcal{U}\}$
is
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
. From the first point of Lawson’s result, we deduce that the infinitesimal preorder of
 $\,{\tilde {\mathcal{\!\!X}}}_{{G}}$
is
 ${{C}}_{{{G}}}$
.
The following lemmas derive from the fact that given atlases
 $\mathcal{A}_{{}}$
and
 $\mathcal{B}_{{}}$
, partial curves (resp. piecewise smooth paths) on
 $\mathcal{A}_{{}} \times \mathcal{B}_{{}}$
are of the form
 $\alpha \times \beta$
with
 $\alpha$
and
 $\beta$
partial curves (resp. piecewise smooth paths) on
 $\mathcal{A}_{{}}$
and
 $\mathcal{B}_{{}}$
.
Lemma 5.39.
If
 $C$
and
 $D$
are the infinitesimal preorders of local orders
 $\mathcal{X}_{{}}$
and
 $\mathcal{Y}_{{}}$
, then
 $C \times D$
is the infinitesimal preorder of the local order
 $\mathcal{X}_{{}} \times \mathcal{Y}_{{}}$
.
Proof.
Let
 $U\in \mathcal{X}_{{}}$
,
 $V\in \mathcal{Y}_{{}}$
, and
 $(p,q)\in U \times V$
. A tangent vector
 $v\in {{T}}_{{{(p,q)}}}(\mathcal{A}_{{}} \times \mathcal{B}_{{}})$
is a subtangent vector of
 $\{(p,q)\:{{\preccurlyeq }}_U \times {{\preccurlyeq }}_V\:(u,v)\mid (u,v)\in U \times V\}$
when there exists a partial curve
 $\gamma :D\to |\mathcal{A}_{{}}| \times |\mathcal{B}_{{}}|$
with
 $\gamma (0)=(p,q)$
,
 $\gamma (0)\:{{\preccurlyeq }}_U \times {{\preccurlyeq }}_V\:\gamma (t)$
for every
 $t\in D\setminus \{0\}$
and
 \begin{equation*} {{[[{{v}}]]}}_{{{(p,q)}}}^{{{\phi \times \psi }}} = \lim _{0\leftarrow t\in D} \tfrac 1t \big ((\phi \times \psi )(\gamma (t)) - (\phi \times \psi )(p,q) \big ). \end{equation*}
The vector space
 ${{T}}_{{{(p,q)}}}(\mathcal{A}_{{}} \times \mathcal{B}_{{}})$
is isomorphic to
 ${{T}}_{{{p}}}\mathcal{A}_{{}} \times {{T}}_{{{q}}}\mathcal{B}_{{}}$
so we can suppose that
 ${{[[{{\_}}]]}}_{{{(p,q)}}}^{{{\phi \times \psi }}}={{[[{{\_}}]]}}_{{{p}}}^{{{\phi }}} \times {{[[{{\_}}]]}}_{{{q}}}^{{{\psi }}}$
and
 $v=(a,b)$
with
 $a\in {{T}}_{{{p}}}\mathcal{A}_{{}}$
and
 $b\in {{T}}_{{{q}}}\mathcal{B}_{{}}$
. It follows that
 $\gamma =\alpha \times \beta$
with
 $\alpha :D\to |\mathcal{A}_{{}}|$
and
 $\beta :D\to |\mathcal{A}_{{}}|$
partial curves satisfying
 $\alpha (0)=p$
,
 $\beta (0)=q$
,
 $\alpha (0)\:{{\preccurlyeq }}_U\:\alpha (t)$
, and
 $\beta (0)\:{{\preccurlyeq }}_V\:\beta (t)$
for every
 $t\in D\setminus \{0\}$
, and
 \begin{equation*} {{[[{{a}}]]}}_{{{p}}}^{{{\phi }}} \:\:= \lim _{0\leftarrow t\in D} \tfrac 1t \big (\phi (\alpha (t)) - \phi (p) \big ) \:\quad \text{and}\quad \: {{[[{{b}}]]}}_{{{q}}}^{{{\psi }}} \:\:= \lim _{0\leftarrow t\in D} \tfrac 1t \big (\psi (\beta (t)) - \psi (q) \big ). \end{equation*}
This is equivalent to having
 $a$
and
 $b$
subtangent vectors of
 $\{p\:{{\preccurlyeq }}_U\:u\mid u\in U\}$
and
 $\{q\:{{\preccurlyeq }}_V\:v\mid v\in V\}$
.
Lemma 5.40.
If
 $\mathcal{X}_{{}}$
and
 $\mathcal{Y}_{{}}$
are local orders associated with upper semi-continuous cone fields
 $C$
and
 $D$
, then the local order
 $\mathcal{X}_{{}} \times \mathcal{Y}_{{}}$
is associated with the cone field
 $C \times D$
.
Proof.
Having a smooth path
 $\gamma$
on
 $\mathcal{A}_{{}} \times \mathcal{B}_{{}}$
from
 $(p,q)$
to
 $(u,v)$
, satisfying
 $d(\gamma )(t)\in C(\alpha (t)) \times D(\beta (t))$
for every
 $t\in \textit {dom}\:(\gamma )$
, is equivalent to having smooth paths
 $\alpha$
and
 $\beta$
on
 $\mathcal{A}_{{}}$
and
 $\mathcal{B}_{{}}$
(both defined on
 $\textit {dom}\:(\gamma )$
), respectively, from
 $p$
to
 $u$
and from
 $q$
to
 $v$
, such that
 $d\alpha (t)\in C(\alpha (t))$
and
 $d\beta (t)\in D(\beta (t))$
for every
 $t\in \textit {dom}\:(\gamma )$
. In other words, we have
 $(p,q)\:{{\preccurlyeq }}_{U \times V}\:(u,v)$
if, and only if,
 $p\:{{\preccurlyeq }}_U\:u$
and
 $q\:{{\preccurlyeq }}_V\:v$
, that is,
 $(p,q)\:{{\preccurlyeq }}_U \times {{\preccurlyeq }}_V\:(u,v)$
.
Let
 $({{G}}_{{1},\ldots ,{{G}}_{n}})$
be a tuple of graphs. For each
 $k\in \{{1},\ldots ,{n}\}$
, we have the standard local order
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_{k}}}$
(Def. 5.15) and the standard cone field
 ${{C}}_{{{G_{k}}}}$
(Def. 5.36) on the set
 $\|{{{G}}_{{{k}}}}\|$
. As an immediate consequence of Prop. 5.38 and Lem. 5.39 and 5.40, we have:
Theorem 5.41.
The cone field
 ${{C}}_{{{G_1}}} \times \cdots \times {{C}}_{{{G_{n}}}}$
and the local order
 $\,{\tilde {\mathcal{\!\!X}}}_{{G_1}} \times \cdots \times \,{\tilde {\mathcal{\!\!X}}}_{{G_{n}}}$
are deduced from each other along Lawson’s correspondence.
6. Execution Time
The smooth model
 $\|{P}\|$
of a program
 $P$
(Def. 2.22) is equipped with a pseudometric inherited from that of
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
, while the pseudometric of each
 $\|{{{G}}_{{{i}}}}\|$
is derived from
 ${{\ell }}_i:{{G}}_{(1)}^{{i}}\to [{{R}},{{\infty }}[$
(Def. 4.14). The pseudometric of
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
also depends on a parameter
 $\alpha \in [{{1}},{{\infty }}]$
(Def. 4.17). In order that the length of a directed path on
 $\|{P}\|$
coincides with the execution time of its sequence of multi-instructions, we should take
 $\alpha =\infty$
. We explain why in §6.1 and prove in §6.2 that directed paths admit piecewise affine approximations (Thm. 6.5 and Cor. 6.6). A similar discussion can be found in (Dang and Gerner, Reference Dang and Gerner2004, §3.4).
6.1 The parallel execution time principle
If several tasks that have started at the same time are executed in parallel (i.e. simultaneously and independently of each other), then the time required to complete all of them is the time required to complete the longest one; we refer to this claim as the parallel execution time principle. As a consequence of it, the time required to execute a multi-instruction
 $\mu$
on a machine allowing parallel execution (we call it the parallel execution time of
 $\mu$
) is
 \begin{equation} \max \big \{\:T_i\ \big |\ \big \}{i\in \textit {dom}\:\mu \:} \end{equation}
with
 ${{T}}_{{{i}}}$
being the time required by the
 $i^{th}$
process to execute the instruction
 $\mu (i)$
(for
 $i\in \textit {dom}\:\mu$
).
In comparison, if several tasks are performed sequentially (i.e. one task starts the moment the previous one ends), then the time required to complete all of them is the sum of the times required to complete each of them; we refer to this claim as the sequential execution time principle. Consequently, the time required to execute a multi-instruction
 $\mu$
on a sequential machine (we call it the sequential execution time of
 $\mu$
) is
 \begin{equation} \sum _{i\in \textit {dom}\:\mu \:}T_i\:. \end{equation}
Consider a directed smooth path
 $\gamma$
(Def. 5.7 and A.7) representing an execution trace (see the end of the preamble of §5, p. 21). On an infinitesimal scale, the path
 $\gamma$
at
 $t$
is identified with the segment from
 $\gamma (t)$
to
 $\gamma (t)+\gamma '(t)$
, which represents the execution of an “infinitesimal multi-instruction”
 $d\mu$
. Put
 $\gamma '(t)=({{\gamma '}}_{{{1}}}(t),\ldots ,{{\gamma '}}_{{{n}}}(t))$
and assume that
 $|{{\gamma '}}_{{{i}}}(t)|$
is the time spent by the
 $i^{th}$
process to execute the
 $i^{th}$
component of
 $d\mu$
(with the convention that
 $|{{\gamma '}}_{{{i}}}(t)|=0$
when
 $i\not \in \textit {dom}\:(d\mu )$
). As a consequence of (19) and (20), the parallel execution time of
 $d\mu$
is
 ${{|\gamma '(t)|}}_{{{\infty }}}=\max \big \{\:|{{\gamma '}}_{{{i}}}(t)|\ \big |\ i\in \{{1},\ldots ,{n}\}\:\big \}$
, while the sequential execution time of
 $d\mu$
is
 ${{|\gamma '(t)|}}_{{{1}}}=|{{\gamma '}}_{{{1}}}(t)|+\cdots +|{{\gamma '}}_{{{n}}}(t)|$
. Hence the parallel and the sequential execution times of the sequence of multi-instructions represented by
 $\gamma$
are, respectively,
 \begin{equation*} {\mathcal L}^{{\:\infty }}(\gamma )= \int _{x}^{y}{{|\gamma '(t)|}}_{{{\infty }}}\: dt \qquad \text{and} \qquad {\mathcal L}^{{\:1}}(\gamma )= \int _{x}^{y}{{|\gamma '(t)|}}_{{{1}}}\: dt \end{equation*}
with
 $[{{x}},{{y}}]=\textit {dom}\:(\gamma )$
– see Def. 4.22. We observe that
 \begin{equation*} \int _x^y{{|{\gamma '(t)}|}}_{{{1}}}dt = \int _x^y\Big (\sum _{i=1}^n|\gamma '_i(t)|dt \Big ) = \sum _{i=1}^n\Big (\int _x^y|\gamma '_i(t)|dt \Big ) \end{equation*}
which confirms that the sequential execution time does not depend on the schedule (see the discussion that follows Def. 2.13, p. 8). This is wrong for the parallel execution time principle: by considering the directed (piecewise) smooth paths
 $\gamma :t\in [0,1]\mapsto (t,t)\in [0,1]^2$
and
 \begin{equation*} \delta :t\in [0,1]\mapsto \left \{ \begin{array}{ll} (0,2t) & \text{if } 0\leqslant t\leqslant \tfrac 12\\ (2t-1,1) & \text{ if } \tfrac 12\leqslant t\leqslant 1 \end{array} \right . \end{equation*}
we have
 ${\mathcal L}^{{\:1}}(\gamma )={\mathcal L}^{{\:1}}(\delta )={\mathcal L}^{{\:\infty }}(\delta )=2$
, while
 ${\mathcal L}^{{\:\infty }}(\gamma )=1$
. The ratio
 $\frac {{\mathcal L}^{{\:1}}(\gamma )}{{\mathcal L}^{{\:\infty }}(\gamma )}$
indicates the efficiency of the schedule corresponding to a directed smooth path
 $\gamma$
on the smooth model of a program (the greater the better). See (Cormen et al., Reference Cormen, Leiserson, Rivest and Stein2022, p. 757–759) and (Herlihy et al., Reference Herlihy, Shavit, Luchangco and Spear2020, §16.2, p. 384–386) for related discussions.
Let
 $M$
be the model of a program
 $P$
. We denote by
 $dM$
the set of directed paths on
 $M$
. Two points of
 $M$
are said to be equivalent when they belong to the same tile (Def. 2.11); two elements of
 $dM$
are said to be equivalent when so are their extremities and their sequences of multi-instructions have the same effect on the system – see §1 or (Haucourt, Reference Haucourt2018, §6). We have just seen that
 $M$
admits a metric such that the length of a directed path on
 $M$
is the execution time of its sequence of multi-instructions, so it seems natural to minimize length in order to optimize execution time. However, a constant path and a directed loop on
 $M$
with the same extremities are not equivalent in general. Therefore, assuming that
 $\sigma$
is the sequence of multi-instructions of
 $\gamma \in dM$
, when it comes to replacing
 $\sigma$
by a faster sequence of multi-instructions doing the same job, we cannot just replace
 $\gamma$
by a shorter directed path with equivalent extremities. Nevertheless, assuming that
 $dM$
is equipped with the distance defined by
 \begin{equation*} d({{\delta }}_{{{0}}},{{\delta }}_{{{1}}}) = \max \{d({{\delta }}_{{{0}}}(t),{{\delta }}_{{{1}}}(t))\mid t\in J\} \end{equation*}
for all
 ${{\delta }}_{{{0}}}$
,
 ${{\delta }}_{{{1}}}\in dM$
such that
 $\textit {dom}\:({{\delta }}_{{{0}}})=\textit {dom}\:({{\delta }}_{{{1}}})=J$
, there is an open ball
 $B$
centered at
 $\gamma$
such that for every
 $\delta \in B$
, the directed paths
 $\gamma$
and
 $\delta$
are equivalent when so are their extremities (Haucourt, Reference Haucourt2018, Thm. 6.1). We easily obtain a possible radius for
 $B$
as follows. We define the set of atomic instructions appearing in a multi-instruction
 $\mu$
as
 $A(\mu )=\{{{\mu }}_i\mid i\in \textit {dom}\:(\mu )\}$
, and the set of atomic instructions appearing in a sequence of multi-instructions
 ${{\mu }}_{{1},\ldots ,{{\mu }}_{k}}$
as the union
 ${A}({{\mu }}_{1}){\cup }\cdots {\cup }{A}({{\mu }}_{k})$
. The smallest execution time of the atomic instructions appearing in
 $\sigma$
can be taken as the radius of
 $B$
. This result allows local optimizations based on purely geometric considerations, a topic which is discussed further in §7.
6.2 Piecewise affine approximations
As long as we are only interested in minimizing the length of directed paths between two points of a tile-compatible set (Def. 2.11 and 2.15), we can restrict our attention to piecewise affine paths (Def. 4.4): this claim is formalized in Thm. 6.5 and Cor. 6.6.
The sets
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
and
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
are equipped with their standard local orders (Def. 5.11 and 5.15) from which their topologies are inherited (§5.2, p. 23). The pseudometrics
 ${{d}}_{{{i}}}$
on
 $|{{{G}}_{{{i}}}}|$
and
 $\|{{{G}}_{{{i}}}}\|$
are given by Def. 4.5 and 4.14. Following execution time considerations (§6.1), the chosen product metric is
 \begin{equation*} {{d}}^{{({\infty })}}\big (({{p}}_{{1},\ldots ,{{p}}_{n}}),({{q}}_{{1},\ldots ,{{q}}_{n}})\big ) = \max \big \{{{d}}_{{{i}}}({{p}}_{{{i}}},{{q}}_{{{i}}})\ \big |\ i\in \{{1},\ldots ,{n}\}\big \}. \end{equation*}
Let
 $\gamma :I\to X$
be a path with
 $X$
a subset of
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
or
 $\|{{{G}}_{{{1}}}}\| \times \cdots \times \|{{{G}}_{{{n}}}}\|$
.
Definition 6.1.
For
 $\varepsilon \gt 0$
, an
 $\varepsilon$
-approximation of
 $\gamma$
on
 $X$
is a path
 $\alpha :I\to X$
such that:
-
–
$\alpha$
and
$\gamma$
have the same starting and the same finishing points,
-
–
$\alpha$
and
$\gamma$
are
$\varepsilon$
-close, that is
${{d}}^{{({\infty })}}(\alpha (t),\gamma (t))\lt \varepsilon$
for every
$t\in I$
, -
–
$\alpha$
is not longer than
$\gamma$
, and
-
– if
$\gamma$
is directed, then so is
$\alpha$
.


Any path is clearly its own
 $\varepsilon$
-approximation whatever
 $\varepsilon$
and
 $X$
are. From now on, we assume that
 $X$
is tile-compatible; our goal is to prove that any directed path
 $\gamma$
on
 $X$
has a piecewise affine
 $\varepsilon$
-approximation for arbitrarily small
 $\varepsilon \gt 0$
. We first deal with the case where
 $X\subseteq |{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
, which requires more technicalities.
Definition 6.2.
An open ball
 $B$
of radius
 $r$
in the metric space
 $(|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|,{{d}}^{{({\infty })}})$
is said to be admissible when
 $r\leqslant \tfrac R4$
and for every
 $k\in \{{1},\ldots ,{n}\}$
, if the
 $k^{th}$
projection of the center of
 $B$
is not a vertex, then the
 $k^{th}$
projection of
 $B$
contains no vertex. Given
 $\varepsilon \gt 0$
, an
 $\varepsilon$
-discretization of a path
 $\gamma :[{{x}},{{y}}]\to |{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
is a sequence
 $x={{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}\leqslant y$
with admissible open balls
 ${{B}}_{{0},\ldots ,{{B}}_{k}}$
such that i) each
 ${{B}}_{{{i}}}$
is centered at
 $\gamma ({{t}}_{{{i}}})$
with radius at most
 $\varepsilon$
, ii) for every
 $i\in \{{1},\ldots ,{k}\}$
,
 $]{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}[\:\cap \:{{\gamma }}^{{-1}}({{B}}_{{{i-1}}}\cap {{B}}_{{{i}}})\not =\emptyset$
, and iii)
 $\textit {img}\:(\gamma )\subseteq {{B}}_{0}{\:\cup \:}\cdots {\:\cup \:}{{B}}_{k}$
.
Lemma 6.3.
Denote by
 $p$
the center of an admissible open ball
 $B$
. For every
 $q\in B$
and every
 $k\in \{{1},\ldots ,{n}\}$
, the shortest path from
 ${{p}}_{{{k}}}$
to
 ${{q}}_{{{k}}}$
(the
 $k^{th}$
projections of
 $p$
and
 $q$
) is the dash
 ${{p}}_{{{k}}}\to {{q}}_{{{k}}}$
(Def. 4.7
, p. 15). The higher dimensional dash
 $p\to q=({{p}}_{{{1}}}\to {{q}}_{{{1}}}) \times \cdots \times ({{p}}_{{{n}}}\to {{q}}_{{{n}}})$
(with affine parametrization) is of length
 $d(p,q)$
and its image is contained in the union of the tiles containing
 $p$
and
 $q$
, respectively. Moreover, if
 $p\:{{\leqslant }}_U\:q$
(resp.
 $q\:{{\leqslant }}_U\:p$
) for some pospace
 $U$
of the standard local order
 $\mathcal{X}_{{G_1}} \times \cdots \times \mathcal{X}_{{G_n}}$
(Def. 5.11
, p. 25), then
 $p\to q$
(resp.
 $q\to p$
) induces (as a map) a pospace morphism with values in
 $U$
, and therefore a directed path on
 $\mathcal{X}_{{G_1}} \times \cdots \times \mathcal{X}_{{G_n}}$
.
Proof.
The
 $k^{th}$
projection of
 $B$
is the open ball of
 $|{{{G}}_{{{k}}}}|$
centered at
 ${{p}}_{{{k}}}$
with radius
 $r\leqslant \tfrac R4$
, we denote it by
 ${{B}}_{{{k}}}$
. The shortest path
 ${{\alpha }}_{{{k}}}$
from
 ${{p}}_{{{k}}}$
to
 ${{q}}_{{{k}}}$
is either of the form
 ${{p}}_{{{k}}}\to {{q}}_{{{k}}}$
or
 ${{p}}_{{{k}}}\to {{v}}_{{{k}}}\to {{q}}_{{{k}}}$
for a unique vertex
 ${{v}}_{{{k}}}$
(Lem. 4.10, p. 16). We have
 $\textit {img}\:({{\alpha }}_{{{k}}})\subseteq {{B}}_{{{k}}}$
because the distance from any point along
 ${{\alpha }}_{{{k}}}$
to
 ${{p}}_{{{k}}}$
is less that
 ${{d}}_{{{|{G_k}|}}}({{p}}_{{{k}}},{{q}}_{{{k}}})$
; it follows that if
 ${{\alpha }}_{{{k}}}={{p}}_{{{k}}}\to {{v}}_{{{k}}}\to {{q}}_{{{k}}}$
, then
 ${{p}}_{{{k}}}={{v}}_{{{k}}}$
because
 ${{B}}_{{{k}}}$
contains no vertex otherwise (
 $B$
is admissible). Let
 ${{\tau }}_{{{k}}}$
be the
 $k^{th}$
projection of the tile
 $\tau$
containing
 $q$
. Suppose that
 $\textit {dom}\:({{\alpha }}_{{{k}}})=[{{{{t}}_{{{0}}}}},{{{{t}}_{{{1}}}}}]$
, since the path
 ${{\alpha }}_{{{k}}}$
is an arc (Rem. 4.9) and
 ${{\alpha }}_{{{k}}}({{t}}_{{{0}}})={{p}}_{{{k}}}$
, we deduce from Def. 4.7 that
 ${{\alpha }}_{{{k}}}(]{{{{t}}_{{{0}}}}},{{{{t}}_{{{1}}}}}])\subseteq {{\tau }}_{{{k}}}$
. Assuming that all the paths
 ${{\alpha }}_{{{k}}}$
(for
 $k\in \{{1},\ldots ,{n}\}$
) are defined on
 $[{{{{t}}_{{{0}}}}},{{{{t}}_{{{1}}}}}]$
, the path
 $\alpha ={{\alpha }}_{1}{ \times }\cdots { \times }{{\alpha }}_{n}$
on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
satisfies
 $\alpha (]{{{{t}}_{{{0}}}}},{{{{t}}_{{{1}}}}}])\subseteq \tau$
. The last point is readily deduced from Def. 4.7 (p. 15) and 5.11 (p. 25).
Lemma 6.4.
For every
 $\varepsilon \gt 0$
, every path
 $\gamma$
on
 $|{{{G}}_{{{1}}}}| \times \cdots \times |{{{G}}_{{{n}}}}|$
admits an
 $\varepsilon$
-discretization.
Proof.
Suppose that
 $\textit {dom}\:(\gamma )=[{{x}},{{y}}]$
and denote by
 ${{t}}_{{{\infty }}}$
the least upper bound of the set of elements
 $t\in [{{x}},{{y}}]$
such that the restriction
 ${{{\gamma }|}}_{{{{[{{x}},{{t}}]}}}}$
has an
 $\varepsilon$
-discretization. Choose an admissible open ball
 ${{B}}_{{{\infty }}}$
centered at
 $\gamma ({{t}}_{{{\infty }}})$
with radius less than
 $\varepsilon$
. Let
 $t\lt {{t}}_{{{\infty }}}$
such that
 $\gamma [{{t}},{{{{t}}_{{{\infty }}}}}]\subseteq {{B}}_{{{\infty }}}$
. Let
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}\leqslant t$
with open balls
 ${{B}}_{{0},\ldots ,{{B}}_{k}}$
be an
 $\varepsilon$
-discretization of the restriction
 ${{{\gamma }|}}_{{{{[{{x}},{{t}}]}}}}$
. Even if it means taking
 $t$
a bit bigger, we can suppose that
 ${{t}}_{{{k}}}\lt t\lt {{t}}_{{{\infty }}}$
with
 $\gamma (t)\in {{B}}_{{{k}}}\cap {{B}}_{{{\infty }}}$
. Then
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}\lt {{t}}_{{{\infty }}}\leqslant {{t}}_{{{\infty }}}$
with open balls
 ${{B}}_{{0},\ldots ,{{B}}_{k}},{{B}}_{{{\infty }}}$
is an
 $\varepsilon$
-discretization of the restriction
 ${{{\gamma }|}}_{{{{[{{x}},{{{{t}}_{{{\infty }}}}}]}}}}$
. If we had
 ${{t}}_{{{\infty }}}\lt y$
, then we would have
 $t'\in \:]{{{{t}}_{{{\infty }}}}},{{y}}[$
such that
 $\gamma [{{{{t}}_{{{\infty }}}}},{{t'}}]\subseteq {{B}}_{{{\infty }}}$
so the previous
 $\varepsilon$
-discretization of
 ${{{\gamma }|}}_{{{{[{{x}},{{{{t}}_{{{\infty }}}}}]}}}}$
would also be an
 $\varepsilon$
-discretization of
 ${{{\gamma }|}}_{{{{[{{x}},{{t'}}]}}}}$
, which would contradict the definition of
 ${{t}}_{{{\infty }}}$
.
We deduce the approximation results:
Theorem 6.5.
For every
 $\varepsilon \gt 0$
, every path
 $\gamma$
on a tile-compatible subset
 $X$
of
 $|{{{{G}}}_{{{{1}}}}}| \times \cdots \times |{{{{G}}}_{{{{n}}}}}|$
admits a piecewise affine
 $\varepsilon$
-approximation.
Proof.
Let
 $\varepsilon \gt 0$
and suppose that
 $x={{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}\leqslant y$
with the admissible open balls
 ${{B}}_{{0},\ldots ,{{B}}_{k}}$
is an
 $\varepsilon$
-discretization of the path
 $\gamma :[{{x}},{{y}}]\to X$
(Lem. 6.4). In particular,
 $\gamma ({{t}}_{{{i}}})$
is the center of
 ${{B}}_{{{i}}}$
for every
 $i\in \{{0},\ldots ,{k}\}$
. For every
 $i\in \{{1},\ldots ,{k}\}$
, choose
 ${{t'}}_{{{i}}}\in \:]{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}[$
such that
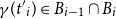 $\gamma ({{t'}}_{{{i}}})\in {{B}}_{{{i-1}}}\cap {{B}}_{{{i}}}$
and define
 ${{t}}_{{{{k+1}}}}'=y$
. For every
 $i\in \{{0},\ldots ,{k}\}$
, we have a step
 ${{s}}_{{{i}}}$
(Def. 4.3) from
 $\gamma ({{t}}_{{{i}}})$
to
 $\gamma ({{t'}}_{{{{i+1}}}})$
whose image is included in
 $X$
(apply Lem. 6.3 with
 $p=\gamma ({{t}}_{{{i}}})$
and
 $q=\gamma ({{t'}}_{{{{i+1}}}})$
observing that
 $X$
is tile compatible and contains the endpoints of
 ${{s}}_{{{i}}}$
). Similarly, we have, for
 $i\in \{{1},\ldots ,{k}\}$
, a step
 ${{{s}}_{{{i}}}}'$
from
 $\gamma ({{t'}}_{{{i}}})$
to
 $\gamma ({{t}}_{{{i}}})$
whose image is included in
 $X$
. The concatenation
 ${{s}}_{{{0}}}{{{s}}_{{{1}}}}'{{s}}_{{{1}}}\cdots {{{s}}_{{{k}}}}'{{s}}_{{{k}}}$
is the expected piecewise affine
 $\varepsilon$
-approximation.
Corollary 6.6.
For every
 $\varepsilon \gt 0$
, every directed path
 $\gamma$
on a tile-compatible subset
 $X$
of
 $\|{{{{G}}}_{{{{1}}}}}\| \times \cdots \times \|{{{{G}}}_{{{{n}}}}}\|$
admits a piecewise affine
 $\varepsilon$
-approximation on
 $X$
.
Proof.
The directed path
 $({{\beta }}_{1}{ \times }\cdots { \times }{{\beta }}_{n})\circ \gamma$
on the tile-compatible set
 $({{\beta }}_{1}{ \times }\cdots { \times }{{\beta }}_{n})(X)$
(Lem. 2.19) admits a piecewise affine
 $\varepsilon$
-approximation
 $\alpha$
(Thm. 6.5), which is a directed path (Def. 6.1). The expected approximation is the lifting of
 $\alpha$
(Thm. 5.29).
7. Afterword
7.1 A glimpse of Finsler geometry
Finsler metrics are motivated by the observation that measuring the length of a curve on a manifold
 $\mathcal{M}$
only requires a way of measuring the length of tangent vectors, see (Papadopoulos, Reference Papadopoulos2013, p. 40), (Chern and Shen, Reference Chern and Shen2005, p. 1). In this context, we call action functional any map
 $F:T\mathcal{M}\to \mathbb{R}_{{+}}$
such that
 $F(x+y)\leqslant F(x)+F(y)$
and
 $F(\lambda x)=\lambda F(x)$
for all
 $p\in \mathcal{M}$
,
 $x$
,
 $y\in T_{p}\mathcal{M}$
, and
 $\lambda \gt 0$
. As suggested by (Bao et al., Reference Bao, Chern and Shen2000, p. 1, 2), the action functional can be chosen so that the length of a curve has a physical meaning: in such a context, minimizing length amounts to minimizing action. Given a parallelization
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
of
 $\mathcal{M}$
and a norm
 ${{|{\_}|}}_{{{\star }}}$
on
 ${\mathbb{R}}^n$
, the mapping
 $(p,v)\:\in \:T\mathcal{M}\:\mapsto \:{{|(a_1,\ldots ,a_n)|}}_{{{\star }}}\:\in \:\mathbb{R}_{{+}}$
with
 $v={{a}}_{{{1}}}{{f}}_{{{1}}}(p)+\cdots +{{a}}_{{{n}}}{{f}}_{{{n}}}(p)$
is an action functional that we still denote by
 ${{|{\_}|}}_{{{\star }}}$
(Def. B.13). When the norm on
 ${\mathbb{R}}^n$
is
 ${{|{\_}|}}_{{{\infty }}}$
the length of
 $\gamma$
is the time required to execute the sequence of multi-instructions represented by
 $\gamma$
; see §6.1 and compare to the navigation problem (Chern and Shen, Reference Chern and Shen2005, 1.4).
A Finsler metric is a family of Minkowski norms on
 $T_{p}\mathcal{M}$
smoothly varying with
 $p\in \mathcal{M}$
(Bao et al., Reference Bao, Chern and Shen2000, p. 5), that is, a map
 $F:T\mathcal{M}\to \mathbb{R}_{{+}}$
, which is smooth on the slit tangent bundle (i.e.
 $T\mathcal{M}\setminus \{\text{ zero tangent vectors}\}$
) and whose restrictions to tangent spaces are Minkowski norms (Chern and Shen, Reference Chern and Shen2005, 1.2.1). These axioms are motivated by the notion of curvature, which plays a central role in the study of both Riemannian and Finsler geometries (Bao et al., Reference Bao, Chern and Shen2000, Introduction).
Although our mathematical framework arises from the same motivations, technicalities rule it out of the scope of standard Finsler geometry. First, manifolds of the form
 $\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}}$
are non-Hausdorff (in all relevant cases) so their topologies are not induced by their (pseudo)metrics. This defect is related to the non-determinism specific to our topic, and it seems impossible to get rid of it. The other issue is that the action functional corresponding to the norm
 ${{|{\_}|}}_{{{\infty }}}$
, which is the one we are interested in (§6.1), fails to be smooth on the slit tangent bundle. Indeed, the norm
 ${{|{\_}|}}_{{{\infty }}}$
is derivative at
 $({{x}}_{{1},\ldots ,{{x}}_{n}})$
if, and only if,
 ${{x}}_{{{i}}}\not ={{x}}_{{{j}}}$
for all
 $i\not =j$
. About this last point, one may argue that “ill-behaved” points form a neglectable closed subset of
 ${\mathbb{R}}^n$
(with respect to Lebesgue measure), so they may be manageable. Actually, the problem of finding minimum action curves in degenerate (i.e. non-smooth) Finsler metrics is studied in (Heymann (Reference Heymann2015)) whose preface indicates concrete situations in which they naturally occur. Heymann’s theory is presented for action functionals defined on
 ${\mathbb{R}}^n$
(Heymann, Reference Heymann2015, Def. 2.4); we are confident that this limitation can be easily overcome, at least for manifolds of the form
 $\mathcal{A}_{{G_1}} \times \cdots \times \mathcal{A}_{{G_n}}$
(Def. 3.3). Heymann theory satisfies many desirable properties (Heymann, Reference Heymann2015, p. 6). In view of applications to geometric models of concurrency, we would like to adapt it to find directed minimizing curves, which would correspond to optimal schedules. This should be compared to the work of Dang and Gerner (Reference Dang and Gerner2004).
7.2 Dealing with the endpoints of a graph
We have observed that the blowup
 ${\beta }_G:\|{G}\|\to |{G}|$
may not be surjective (after Def. 2.15, p. 9); indeed, the elements of the set
 $|{G}|\setminus {\beta }_G(\|{G}\|)$
are the endpoints of
 $G$
, that is, the vertices of
 $G$
without incoming arrow or without outgoing arrow. One can remedy this by means of manifolds with boundary (Bröcker and Jänich, Reference Bröcker and Jänich1982, Chap. 13, p. 129–131), (Guillemin and Pollack, Reference Guillemin and Pollack1974, §1, p. 57), (Lee, Reference Lee2012, p. 25):
Definition 7.1.
A chart with boundary of dimension
 $n\in \mathbb{N}$
, or
 $n$
-chart with boundary, is a bijection
 $\phi$
whose codomain is an open subset of
 $\mathbb{R}_{{+}} \times {\mathbb{R}}^{n-1}$
, with
 $\mathbb{R}_{{+}}=[{{0}},{{\infty }}[$
. A map
 $f:U\to {\mathbb{R}}^m$
with
 $U$
an open subset of
 $\mathbb{R}_{{+}} \times {\mathbb{R}}^{n-1}$
is said to be smooth if it has a smooth extension to an open subset of
 ${\mathbb{R}}^n$
(i.e. there exists an open subset
 $V$
of
 ${\mathbb{R}}^n$
and a smooth map
 $\tilde f:V\to {\mathbb{R}}^m$
such that
 $U\subseteq V$
and
 $f$
is the restriction of
 $\tilde f$
to
 $U$
). Compatibility between charts with boundary is defined as for charts except that the second item of Def. A.2 refers to smooth maps defined on open subsets of
 $\mathbb{R}_{{+}} \times {\mathbb{R}}^{n-1}$
. An atlas with boundary is a collection
 $\mathcal{A}_{{}}$
of pairwise compatible charts with boundary (compare with Def. A.4). The
 $n$
-dimensional atlas (with boundary)
 $\mathcal{A}_{{}}$
induces an
 $(n-1)$
-dimensional atlas (without boundary)
 $\partial \mathcal{A}_{{}}$
on the union of the sets
 ${{\phi }}^{{-1}}(\{0\} \times {\mathbb{R}}^{n-1})$
for
 $\phi$
ranging through
 $\mathcal{A}_{{}}$
(given
 $\phi$
,
 $\psi \in \mathcal{A}_{{}}$
, for every point
 $p\in \textit {dom}\:(\phi )\cap \textit {dom}\:(\psi )$
, we have
 $p\in {{\phi }}^{{-1}}(\{0\} \times {\mathbb{R}}^{n-1})$
if, and only if,
 $p\in {{\psi }}^{{-1}}(\{0\} \times {\mathbb{R}}^{n-1})$
). The atlas
 $\partial \mathcal{A}_{{}}$
is called the boundary of
 $\mathcal{A}_{{}}$
.Footnote
4
Definition 7.2.
The endpoint traversals of
 $G$
are the elements of the set
 \begin{equation*} \partial \|{G}\| = \big \{(a,v),\ (v,b)\ \big |\ \big \}{\ v \text{ endpoint of } G};\ \textrm {tgt}(a)=v;\ \textrm {src}(b)=v, \end{equation*}
and the standard charts with boundary of
 $G$
are the bijections
 \begin{equation*} \begin{gathered} {{\phi }}_{{{av}}}\::\:\{a\} \times {{J}}_{{{a}}}\:\:\cup \:\:\{(a,v)\} \to ]{{\tfrac {-\ell (a)}2}},{{0}}]\\[1mm] \quad \text{with }\quad (a,t)\mapsto t-\ell (a), \quad (a,v)\mapsto 0\end{gathered} \begin{gathered} {{\phi }}_{{{vb}}}\::\:\{(v,b)\}\:\:\cup \:\:\{b\} \times {{I}}_{{{b}}} \to [{{0}},{{\tfrac {\ell (b)}2}}[\\[1mm] {\quad \text{ with }\quad (v,b)\mapsto 0, \quad (b,t)\mapsto t} \end{gathered} \end{equation*}
with
 ${{J}}_{{{a}}}=\:]{{\tfrac {\ell (a)}2}},{{\ell (a)}}[$
,
 ${{I}}_{{{b}}}=\:]{{0}},{{\tfrac {\ell (b)}2}}[$
, and
 $(a,v)$
,
 $(v,b)\in \partial \|{G}\|$
. We define
 $\,\bar {\mathcal{\!\!A}}_{{G}}$
, the standard atlas with boundary of
 $G$
, as the collection of all standard charts of
 $G$
, with or without boundary. We denote by
 ${{\bar \beta }}_{{{G}}}:\|{G}\|\cup \partial \|{G}\|\to |{G}|$
the extension of the blowup map
 ${\beta }_G$
(Def. 2.15
, p. 9) defined by
 ${{\bar \beta }}_{{{G}}}(a,v)={{\bar \beta }}_{{{G}}}(v,b)=v$
for
 $(a,v)$
,
 $(v,b)\in \partial \|{G}\|$
. Note that, unlike
 ${\beta }_G$
, the map
 ${{\bar \beta }}_{{{G}}}$
is surjective.
Remark 7.3.
If
 $X$
is the underlying topology of the standard atlas with boundary of
 $G$
, then
 ${{h}}_{{{X}}}$
the unit at
 $X$
of the adjunction between
 $\mathbf{H}$
and
 $\mathbf{Top}$
(Rem. 5.22) is the map
 ${{\bar \beta }}_{{{G}}}$
.
The map
 ${{\bar \beta }}_{{{G}}}$
should satisfy a universal property similar to that of Thm. 5.33, see Figure 6, p. 43, nevertheless we have not checked the details. The higher dimensional version of this universal property, which concerns
 ${{\bar \beta }}_{1}{ \times }\cdots { \times }{{\bar \beta }}_{n}$
, raises a technical issue: the product of manifolds with boundary is not a manifold with boundary; it is actually a manifold with corners. Roughly speaking, the latter are defined as manifold with boundary, except that
 $\mathbb{R}_{{+}} \times {\mathbb{R}}^{n-1}$
is replaced by
 $\mathbb{R}_{{+}}^n$
– see (Lee, Reference Lee2012, p. 415). One of the subtleties one has to deal with is that for
 ${{k}}_{{{0}}}$
,
 ${{k}}_{{{1}}}\in \{{1},\ldots ,{n}\}$
with
 ${{k}}_{{{0}}}\not ={{k}}_{{{1}}}$
,
 $\mathbb{R}_{{+}}^{k_0} \times {\mathbb{R}}^{n-{k_0}}$
and
 $\mathbb{R}_{{+}}^{k_1} \times {\mathbb{R}}^{n-{k_1}}$
are homeomorphic but not diffeomorphic (Lee, Reference Lee2012, p. 416).
7.3 Hausdorff vs non-Hausdorff manifolds
Apart from a few marginal observations here and there, references dealing with non-Hausdorff manifolds seem to be rare; (Gauld, Reference Gauld2014, Chapter 9) and (Mardani, Reference Mardani2014, §2, p. 61–85) are among the few exceptions. Here are some of the reasons why non-Hausdorff manifolds are ignored: «Non-Hausdorff manifolds occasionally turn up, but it is hard to prove anything interesting about them» (Hirsch, Reference Hirsch1976, pp. 32–33), «Most of the interesting results about manifolds do in fact require these properties.Footnote 5 » (Lee, Reference Lee2012, p. 4), and «…we are not defining manifolds as sets supplied with an atlas […] because […] this […] definition would put us under the obligation to bestow the noble title of manifold upon certain ungainly objects.» (Nestruev, Reference Nestruev2020, §5.6, p. 57). We illustrate these claims with some basic observations which prove that standard facts of differential topology are either wrong or not relevant for non-Hausdorff manifolds:
-
1) There can be more than one integral curve passing through a given point on a non-Hausdorff manifold; compare with (Lang, Reference Lang1999, Thm. 2.1, p. 90). Such a pathology occurs for every standard parallelization (Def. 3.6) whose underlying topology is non-Hausdorff; this is related to the notion of bifurcate curves of the second kind in physics (Hájíček Reference Hájíček1971a, p. 158).
-
2) The Whitney embedding theorem is an emblematic result of differential topology which asserts that every Hausdorff, second countable, smooth manifold
$\mathcal M$
can be smoothly embedded into
${\mathbb{R}}^{2n}$
with
$n$
denoting the dimension of
$\mathcal M$
, see (Whitney, Reference Whitney1944, Thm. 5), or (Adachi, Reference Adachi1993, Thm. 2.11, p. 67), (Benedetti, Reference Benedetti2021, Thm. 7.17, p. 146) for the compact case; most textbooks provide a smooth embedding of
$\mathcal M$
into
${\mathbb{R}}^{2n+1}$
, see (Guillemin and Pollack, Reference Guillemin and Pollack1974, p. 53), (Hirsch, Reference Hirsch1976, Thm. 2.14, p. 55), (Mukherjee, Reference Mukherjee2015, Thm. 2.5.1, p. 62). Conversely, since the collection of Hausdorff (resp. second countable) spaces is stable under subspaces, every manifold
$\mathcal M$
that can be embedded in
${\mathbb{R}}^N$
for some
$N\in \mathbb{N}$
is Hausdorff and second countable. Hence the Whitney embedding theorem does not hold for non-Hausdorff manifolds. -
3) Given a smooth embedding
$\phi :\mathcal M\to {\mathbb{R}}^N$
, the subspace
$\phi (\mathcal M)$
is actually a smooth submanifold of
${\mathbb{R}}^N$
so it inherits a Riemannian metric
$g$
from the Euclidean structure of
${\mathbb{R}}^n$
; the Riemannian metric
$g$
is transferred to
$\mathcal M$
via the embedding
$\phi$
(Lafontaine, Reference Lafontaine2015, p. 223). One can also build a Riemannian metric on
$\mathcal M$
from a partition of unity (Bishop and Crittenden, Reference Bishop and Crittenden1964, Thm. 2, p. 126); indeed, a connected manifold
$\mathcal M$
admits a partition of unity if, and only if, it is Hausdorff and second countable (Brickell and Clark, Reference Brickell and Clark1970, Prop. 3.4.4, p. 51).Footnote
6
Anyway, the topology of a Hausdorff second countable smooth manifold
$\mathcal M$
is induced by any Riemannian metric
$g$
on
$\mathcal M$
(Bishop and Crittenden, Reference Bishop and Crittenden1964, Thm. 1, p. 125). These considerations are often summarized by a concise statement like «every smooth manifold admits a Riemannian metric» (do Carmo, Reference Do Carmo1992, Prop. 2.10, p. 43), or (Lee, Reference Lee2018, Prop. 2.4, p. 11), being assumed that the manifolds under consideration are Hausdorff and second countable. A non-Hausdorff manifold is not metrizable, nevertheless there may be a Riemannian metric on it. For example, every standard atlas (Def. 3.3) can be equipped with a Riemannian metric for which the standard parallelization (Def. 3.6) is orthonormal. As in Def. B.13, the distance between two points
$p$
,
$q$
is the infimum of the lengths of the (smooth) paths from
$p$
to
$q$
, we denote it by
$d(p,q)$
. Then we may have
$p\not =q$
and
$d(p,q)=0$
(Ex. 4.23) so the corresponding topology is not
${{T}}_{{{0}}}$
, while the topology of the atlas is
${{T}}_{{{1}}}$
(Lem. A.9). This suggests that the standard tools of differential geometry are of little help as soon as we have to deal with the topology of non-Hausdorff manifolds. -
4) The connected subsets of the circle are the only
$1$
-dimensional connected metrizable manifolds with boundary, see (Milnor, Reference Milnor1965, Appendix) or (Gale (Reference Gale1987)), while the collection of
$1$
-dimensional standard atlases (Def. 3.3) is infinite (up to diffeomorphism). To see this we define
$N(G,a,b)$
as the number of vertices of
$G$
with
$a$
incoming arrows and
$b$
outgoing arrows, for every finite graph
$G$
and every
$(a,b)\in \mathbb{N} \times \mathbb{N}$
such that
$ab\not =0$
and
$a+b\not =2$
. If
$N(G,a,b)\not = N(G',a,b)$
then the standard atlases
$\mathcal{A}_{{G}}$
and
$\mathcal{A}_{{G'}}$
are not diffeomorphic. The classification of standard atlases remains rather tractable because it only depends on a rather simple classification of graphs (which we do not provide here); however, «a reasonable classification of non-Hausdorff manifolds seems infeasible even in dimension 1» (Gauld, Reference Gauld2014, p. 153).Footnote
7
This claim is to be compared with the classification theorems for metrizable manifolds in dimension
$2$
– see (Hirsch, Reference Hirsch1976, Thm. 3.5, p. 204), (Gauld, Reference Gauld1982, Chapter 14), or (Massey, Reference Massey1991, Thm. 5.1, p. 9)), in dimension
$3$
– see (Hempel, Reference Hempel1976, Thm. 3.21, p. 35) or (Jaco, Reference Jaco1980, II.4, p. 20), and in dimension
$n\geqslant 5$
– see (Kreck (Reference Kreck, Cappell, Ranicki and Rosenberg1999)).Footnote
8
The branching topology of a manifold (which will be defined below), gives a concrete insight of how complicated a non-Hausdorff manifold might be. -
5) Every point
$p$
of a manifold
$\mathcal M$
is contained in an open Hausdorff submanifold
$V$
of
$\mathcal M$
: it suffices to consider a chart of
$\mathcal M$
whose domain contains
$p$
. One can even suppose that
$V$
is maximal with respect to inclusion (Hájíček Reference Hájíček1971b, Thm. 1). The collection of finite intersections of maximal open Hausdorff submanifolds of
$\mathcal M$
is a
$\cap$
-semilattice (i.e. the greatest lower bound of two elements is their intersection) which we call the branching semilattice of
$\mathcal M$
; the latter is, in particular, a base of a topology (on the underlying set of
$\mathcal M$
) which we call the branching topology of
$\mathcal M$
. By definition, the branching topology of every Hausdorff manifold is the coarsest one. For every point
$p$
of the standard atlas
$\mathcal{A}_{{G}}$
of a graph
$G$
, there is a smallest element of the branching semilattice of
$G$
containing
$p$
; equivalently, the branching topology of
$G$
is Alexandroff-discrete (Arenas (Reference Arenas1999)). To see this, let
${{\|{G}\|}}_{{{\text{S}}}}$
be the set of singular traversals of
$G$
(Def. 2.14, p. 9). Then
$\|{G}\|\setminus {{\|{G}\|}}_{{{\text{S}}}}$
is a subspace of (the underlying topological space of)
$\mathcal{A}_{{G}}$
(Def. A.8). The connected component of
$p\in \|{G}\|\setminus {{\|{G}\|}}_{{{\text{S}}}}$
is the smallest neighborhood of
$p$
in the branching topology of
$\mathcal{A}_{{G}}$
. For every arrow
$a$
we denote by
${{C}}_{{{a}}}$
the connected component of
$\|{G}\|\setminus {{\|{G}\|}}_{{{\text{S}}}}$
containing
$\{a\} \times ]{{0}},{{\ell (a)}}[$
. Let
$(a,b)$
be a traversal of
$G$
. If
$(a,b)$
is regular then
${{C}}_{{{a}}}={{C}}_{{{b}}}$
and it is the smallest neighborhood of
$(a,b)$
in the branching topology of
$\mathcal{A}_{{G}}$
. If
$(a,b)$
is singular, then
${{C}}_{{{a}}}\cup \{(a,b)\}\cup {{C}}_{{{b}}}$
is the smallest neighborhood of
$(a,b)$
in the branching topology of
$\mathcal{A}_{{G}}$
.Even if the branching topology of every graph is Alexandrov discrete, the branching semilattice of a graph may not satisfy the descending chain condition; we illustrate this claim:
Let
$Z$
be the graph whose set of vertices is
$\mathbb{Z}$
and such that every vertex
$x$
has exactly one outgoing arrow whose target is
$x+1$
(Ex. 2.20, p. 10). Every graph embedding of
$Z$
into a graph
$G$
induces a manifold embedding of
$\mathbb{R}$
into
$\mathcal{A}_{{G}}$
(see p. 13) whose image is a maximal Hausdorff submanifold of
$\mathcal{A}_{{G}}$
. Suppose that the set of vertices of
$G$
is
$\mathbb{Z} \times \mathbb{Z}$
and that every vertex
$(x,y)$
has exactly two outgoing arrows whose targets are
$(x,y+1)$
and
$(x+1,y)$
. Let
${{H}}_{{{n}}}$
, for
$n\in \mathbb{N}$
, be the maximal Hausdorff submanifold of
$\mathcal{A}_{{G}}$
corresponding to the graph embedding
${{f}}_{{{n}}}:Z\to G$
defined by
${{f}}_{{{n}}}(k)=(k,0)$
for
$k\leqslant -n$
, and by
${{f}}_{{{n}}}(k)=({-}n,n+k)$
for
$k\gt n$
. For every
$n\in \mathbb{N}$
, we have
${{H}}_{0}{\:\cap \:}\cdots {\:\cap \:}{{H}}_{n+1} \:\subsetneq \:{{H}}_{0}{\:\cap \:}\cdots {\:\cap \:}{{H}}_{n}$
. More generally, given a graph
$G$
, if we have a graph embedding of
$Z$
into
$G$
whose image contains infinitely many singular vertices (Def. 2.14, p. 9), then the branching semilattice of
$G$
does not satisfy the descending chain condition.We now provide an example of a manifold whose branching topology is not Alexandrov discrete; it is a special instance of (Mardani, Reference Mardani2014, Ex. 2.4.2, p. 66). The underlying set is
$\{0,1\} \times {\mathbb{R}}$
. For every
$x\in {\mathbb{R}}$
, consider the chart
${{\phi }}_x$
defined on the set
$\{(\varepsilon ,y)\in \{0,1\} \times {\mathbb{R}}\mid \varepsilon =1\Leftrightarrow y=x\}$
by
${{\phi }}_x(\varepsilon ,y)=y$
. Observe that for all
$x$
,
$x'\in {\mathbb{R}}$
with
$x\not =x'$
, we have
$\textit {dom}\:({{\phi }}_x)\cap \textit {dom}\:({{\phi }}_{{{x'}}})=\{0\} \times ({\mathbb{R}}\setminus \{x,x'\})$
, and that the transition map
${{\phi }}_{{{x'}}}\circ {{{{\phi }}_x}}^{{-1}}$
is the identity on
${\mathbb{R}}\setminus \{x,x'\}$
. Hence the collection
$\{{{\phi }}_x\mid x\in {\mathbb{R}}\}$
is an atlas whose corresponding manifold is denoted by
$\mathcal M$
. The maximal open Hausdorff submanifolds of
$\mathcal{M}_{{}}$
are of the form
$(\{0\} \times ({\mathbb{R}}\setminus D))\cup (\{1\} \times D)$
with
$D$
a discrete subset of
$\mathbb{R}$
. Indeed, the mapis a smooth embedding whose derivative at every point is one-to-one (as a linear map); conversely, if
\begin{equation*} x\in {\mathbb{R}} \quad \mapsto \quad \left \{ \begin{array}{ll} (0,x) & \text{ if } x\not \in D\\ (1,x) & \text{ if } x\in D \end{array} \quad \in \quad \{0,1\} \times {\mathbb{R}} \right . \end{equation*}
$f:{\mathbb{R}}\to \mathcal{M}_{{}}$
is a topological embedding, then
${{f}}^{{-1}}(\{1\} \times {\mathbb{R}})$
is a discrete subset of
$\mathbb{R}$
. As a consequence, the elements of the branching semilattice of
$\mathcal{M}_{{}}$
are of the form
$(\{0\} \times ({\mathbb{R}}\setminus {{D}}_{{{0}}}))\cup (\{1\} \times {{D}}_{{{1}}})$
with
${{D}}_{{{1}}}\subseteq {{D}}_{{{0}}}$
discrete subsets of
$\mathbb{R}$
. It follows that the branching topology of
$\mathcal M$
is
${{T}}_{{{1}}}$
, not Alexandrov discrete, yet it is strictly coarser than the manifold topology of
$\mathcal{M}_{{}}$
(e.g. the subset
$\{0\} \times ]0,1[$
is open in the latter, but not in the former). See (Kent et~al. (Reference Kent, Mimna and Tartir2009)) and (Mardani, Reference Mardani2014, §2, p. 61–84) for more topological facts about non-Hausdorff manifolds.
-
6) The “cut and glue” operation on manifolds is of crucial importance in standard differential topology: «A favorite method of studying smooth manifolds consists in observing how they are put together from smaller pieces. The pieces are not, however, smooth manifolds, they are manifolds with boundary.» (Kosinski, Reference Kosinski1993, p. 2). The underlying idea is quite simple: given a submanifold
$B$
of a manifold
$M$
and a manifold
$C$
such that
$\partial B\cong \partial C\not =\emptyset$
(i.e. the boundaries of
$B$
and
$C$
are nonempty and diffeomorphic; see Def. 7.1), one obtains a new manifold
$M'$
by “replacing”
$B$
by
$C$
in
$M$
(for technical reasons,
$M'$
may also depend on the choice of the diffeomorphism
$\phi :\partial B\cong \partial C$
, we can safely ignore this problem here). Informally speaking, we cut
$B$
and glue
$C$
. A crucial property of this construction is that if
$M$
and
$C$
are Hausdorff (resp. metrizable), then so is
$M'$
, see (Hirsch, Reference Hirsch1976, §2, p. 184), (Kosinski, Reference Kosinski1993, VI.4, VI.5, pp. 99–103), or (Wall, Reference Wall2016, §2.7, p. 63) for technical details. A drastically more general construction is possible in the non-Hausdorff framework: instead of “replacing
$B$
by
$C$
” to obtain
$M'$
, one can “add
$C$
without removing
$B$
” to obtain
$M''$
in a way that we have
$b\sim \phi (b)$
for every
$b\in \partial B$
with
$\sim$
as in Rem. 5.22. The boundary of
$B$
is in some sense duplicated, and if
$B=C$
, then the whole submanifold
$B$
is duplicated. For example, by duplicating the submanifold
$[{{1}},{{2}}[$
of the manifold
$]{{0}},{{2}}[$
, that is,
$B=C=[{{1}},{{2}}[$
and
$M=\:]{{0}},{{2}}[$
, we obtain a manifold
$M''$
, which is diffeomorphic to the one shown on Figure 3, see also (Baillif and Gabard, Reference Baillif and Gabard2008, Fig. 1, p. 1106). In particular, we have a canonical embedding of
$M$
(resp.
$M'$
) into
$M''$
, which induces an embedding of the branching topology of
$M$
(resp.
$M'$
) into that of
$M''$
(in general, these embeddings are not homeomorphisms).Figure 6.The standard atlas with boundary of a graph.
-
7) The duplication of submanifolds has further drastic consequences. An atlas (resp. a manifold) is said to be closed when it is compact Hausdorff without boundary. A cobordism between the closed atlases
$\mathcal{A}_{{0}}$
and
$\mathcal{A}_{{1}}$
is a compact Hausdorff atlas
$\mathcal{C}_{{}}$
such that
$\partial \mathcal{C}_{{}}=\mathcal{A}_{{0}}\sqcup \mathcal{A}_{{1}}$
with
$\sqcup$
denoting the disjoint union of manifolds of the same dimension, see (Hirsch, Reference Hirsch1976, §1, pp. 169–172), (Wall, Reference Wall2016, §5.1, p. 129), (Mukherjee, Reference Mukherjee2015, Def. 10.1.3, p. 301). If
$\mathcal{C}_{{}}$
satisfies all the requirements of a cobordism between
$\mathcal{A}_{{0}}$
and
$\mathcal{A}_{{1}}$
but the Hausdorff property, then we say that
$\mathcal{C}_{{}}$
is a non-Hausdorff cobordism, in which case we write
$\mathcal{A}_{{0}}\approx \mathcal{A}_{{1}}$
. Given a closed atlas
$\mathcal{A}_{{}}$
, the cylinder
$\mathcal{A}_{{}} \times [0,1]$
is known as the trivial cobordism from
$\mathcal{A}_{{}}$
to itself. Then
$\mathcal{A}_{{}} \times [{{\tfrac 12}},{{1}}]$
is a submanifold of
$\mathcal{A}_{{}} \times [0,1]$
that can be duplicated to obtain a non-Hausdorff cobordism between
$\mathcal{A}_{{}}$
and
$\mathcal{A}_{{}}\sqcup \mathcal{A}_{{}}$
, that is
$\mathcal{A}_{{}}\approx \mathcal{A}_{{}}\sqcup \mathcal{A}_{{}}$
. We deduce from the equality
$\partial ((\mathcal{A}_{{0}}\sqcup \mathcal{A}_{{1}}) \times [0,1])=\mathcal{A}_{{0}}\sqcup \mathcal{A}_{{0}}\sqcup \mathcal{A}_{{1}}\sqcup \mathcal{A}_{{1}}$
that
$\mathcal{A}_{{0}}\approx \mathcal{A}_{{0}}\sqcup \mathcal{A}_{{1}}\sqcup \mathcal{A}_{{1}}$
, and therefore
$\mathcal{A}_{{0}}\approx \mathcal{A}_{{0}}\sqcup \mathcal{A}_{{1}}$
because
$\mathcal{A}_{{1}}\approx \mathcal{A}_{{1}}\sqcup \mathcal{A}_{{1}}$
. Similarly, we prove that
$\mathcal{A}_{{1}}\approx \mathcal{A}_{{0}}\sqcup \mathcal{A}_{{1}}$
. Hence there is a non-Hausdorff cobordism between any two closed atlases of the same dimension. By contrast, the only
$1$
-dimensional compact Hausdorff connected manifolds (possibly with boundary) are the circle
${{S}}^{{S}{{1}}}$
(
$\partial {{S}}^{{S}{{1}}}=\emptyset$
), and the unit segment
$[0,1]$
(
$\partial [0,1]=\{0,1\}$
), see (Milnor, Reference Milnor1965, Appendix) or (Gale (Reference Gale1987)). Consequently, the boundary of a (possibly not connected)
$1$
-dimensional compact Hausdorff manifold is a
$0$
-dimensional compact Hausdorff manifold, that is, a finite set, whose cardinal is even. It follows that there is a cobordism between two
$0$
-dimensional closed manifolds if, and only if, their cardinals have the same parity.


In the light of the above observations, the gap between Hausdorff and non-Hausdorff manifolds seems to be an abyss. Nevertheless, the standard atlases (Def. 3.3) are so tractable that they are usable by a non-expert. Due to their connection with graphs, which are pervasive in computer science, we believe that they could be relevant to other branches of the discipline. In particular, standard atlases provide a counter-example to the claim «It is exceedingly rare to encounter a space “in nature” that would be a manifold except for the failure of one or the other of these hypotheses.»Footnote 9 (Lee, Reference Lee2012, p. 4).
7.4 Beyond manifolds
The notion of a manifold has been generalized in many different ways, often with the aim of dealing with singularities, which can arise when more than two smooth manifolds are glued along their common boundary (Pflaum, Reference Pflaum2001, p. 1, 2), or when quotients of (finite dimensional) manifolds are considered, for example, in physics (Iglesias-Zemmour, Reference Iglesias-Zemmour2013, Preface; pp. xvii-xx). We are interested in two of these generalizations, and more specifically in their relevance comparing to standard atlases (Def. 3.3 and 7.2).
Diffeological spaces (a.k.a. Souriau spaces) and their morphisms form a quasitopos (Baez and Hoffnung (Reference Baez and Hoffnung2011)) into which the category of smooth manifolds fully embeds; see (Stacey (Reference Stacey2011)) for a categorical comparison with similar kind of “smootheologies.” This means that diffeological spaces provide a framework in which every standard construction on topological spaces is available for manifolds. We provide details and examine a concrete example related to this paper.
A parametrization of dimension
 $n\in \mathbb{N}$
in a set
 $X$
is a map
 $p:U \to X$
where
 $U$
is a domain of dimension
 $n$
, that is, an open subset of
 ${\mathbb{R}}^n$
. A collection
 $\mathcal P$
of
 $n$
-parametrizations in
 $X$
(with
 $n\in \mathbb{N}$
fixed) is said to be glueable when for all
 $p$
,
 $q\in \mathcal P$
, the maps
 $p$
and
 $q$
coincide on
 $\textit {dom}\: p\cap \textit {dom}\: q$
. The glueing of such a collection
 $\mathcal P$
is the
 $n$
-parametrization
 $g$
defined on
 $\bigcup \{\textit {dom}\: p\mid p\in \mathcal P\}$
by
 $g(u)=p(u)$
for any
 $p\in \mathcal P$
such that
 $u\in \textit {dom}\: p$
; we denote the glueing of
 $\mathcal P$
by
 $\cup \mathcal P$
. A diffeology on a set
 $X$
is a collection
 $\mathcal D$
of parametrization in
 $X$
containing all constant parametrizations, and which is closed under gluing and precomposition by smooth maps between domains (because of this last property, a diffeology contains parametrizations in every dimension). The topology of
 $\mathcal D$
is the greatest topology on
 $X$
making all the elements of
 $\mathcal D$
continuous. The collection of constant parametrizations in
 $X$
is a diffeology on
 $X$
, and so is the collection of all parametrizations in
 $X$
. For every smooth manifold
 $\mathcal M$
(with or without boundary, see Def. 7.1), the collection
 $ \{\phi :U\to \mathcal M\mid U \text{ a domain and } \phi \text{smooth}\}$
is a diffeology; we refer to it as the standard diffeology of
 $\mathcal M$
. In particular, the standard diffeology of a domain
 $U$
is the collection
 $\{\phi :V\to U\mid V \text{ domain and } \phi\ \text{smooth}\}$
. Moreover, the collection of diffeologies on
 $X$
is closed under intersection. In particular, for every collection
 $\mathcal P$
of parametrizations in
 $X$
, the diffeology on
 $X$
generated by
 $\mathcal P$
is (by definition) the smallest one containing
 $\mathcal P$
. This gives an insight of how flexible the notion of a diffeology is: any collection of parametrizations in
 ${\mathbb{R}}^n$
(they may not even be continuous) induces a diffeology on
 ${\mathbb{R}}^n$
; in comparison, if
 $n\not =4$
, there is a unique manifold whose underlying topological space is
 ${\mathbb{R}}^n$
(Scorpan, Reference Scorpan2005, p. vii). Given a map
 $f:X\to X'$
, we define
 ${{f}}_{{{\ast }}}\mathcal D$
, the pushforward of
 $\mathcal D$
by
 $f$
, as the diffeology on
 $X'$
generated by
 $f\circ \mathcal D$
. Assuming that
 $f$
is surjective, a parametrization
 $q$
(in
 $X'$
) belongs to
 ${{f}}_{{{\ast }}}\mathcal D$
if, and only if, for every
 $u\in \textit {dom}\:(q)$
there exist an open subset
 $U$
of
 $\textit {dom}\:(q)$
containing
 $u$
, and a parametrization
 $p\in \mathcal D$
with
 $U\subseteq \textit {dom}\:(p)$
such that the restriction of
 $q$
to
 $U$
is the composite
 $f\circ p$
(Iglesias-Zemmour, Reference Iglesias-Zemmour2013, 1.68, p. 41); in other words
 $ {{f}}_{{{\ast }}}\mathcal D = \{\cup \mathcal P\mid \}{\mathcal P\subseteq f\circ \mathcal D\text{ glueable}}$
. Note that, in the preceding criterion, we can always suppose that
 $U$
(resp. every domain on which an element of
 $\mathcal P$
is defined) is connected. Given another diffeology
 $\mathcal D'$
on
 $X'$
, a map
 $f:X\to X'$
is said to be smooth from
 $\mathcal D$
to
 $\mathcal D'$
when
 ${{f}}_{{{\ast }}}\mathcal D\subseteq \mathcal D'$
, which is equivalent to have
 $f\circ \phi \in \mathcal D'$
for every
 $\phi \in \mathcal D$
, that is
 $f\circ \mathcal D\subseteq \mathcal D'$
. Given an equivalence relation
 $\sim$
on the underlying set of a diffeology
 $\mathcal D$
, the quotient diffeology
 $\mathcal D/\sim$
is (by definition), the pushforward
 ${{q}}_{{{\ast }}}{\mathcal D}$
with
 $q$
the quotient map corresponding to
 $\sim$
.
Given a graph
 $G$
and a map
 $\ell :{{G}}^{{({1})}}\to [{{R}},{{\infty }}[$
with
 $R\gt 0$
, the following space is a disconnected union (i.e. coproduct in the category of topological spaces) of intervals:
 \begin{equation*} {{\bar X}}_{{{G}}} = \bigcup \big \{\:\:\{a\} \times [{{0}},{{\ell (a)}}]\:\:\ \big |\ \:\:a\in {{G}}^{{({1})}}\:\:\big \}. \end{equation*}
In particular,
 ${{\bar X}}_{{{G}}}$
is a
 $1$
-dimensional smooth manifold with boundary, hence it induces a diffeology. Let
 $\sim$
be the least equivalence relation such that
 $(a,\ell (a))\sim (b,0)$
when
 $\textrm {tgt}\; a =\textrm {src}\; b$
,
 $(a,0)\sim (b,0)$
when
 $\textrm {src}\ a=\textrm {src}\; b$
, and
 $(a,\ell (a))\sim (b,\ell (b))$
when
 $\textrm {tgt}\; a=\textrm {tgt}\ b$
. The underlying topological space of the quotient diffeology
 ${{\bar X}}_{{{G}}}/\sim$
is the geometric realization of
 $G$
(Def. 2.10, p. 7). This topology is the largest one making the quotient map
 $q:{{\bar X}}_{{{G}}}\to |{G}|$
associated with
 $\sim$
continuous; it is also the largest one making the map
 ${{\bar \beta }}_{{{G}}}$
(Def. 7.2) continuous. So the set
 $|{G}|$
admits two “natural” diffeologies with the same underlying topology: the first one is
 ${{\mathcal D}}_{{{{1}}}}={{q}}_{{{\ast }}}({{\bar X}}_{{{G}}})$
the pushforward of the (Hausdorff) manifold with boundary
 ${{\bar X}}_{{{G}}}$
by
 $q$
, the second one is
 ${{\mathcal D}}_{{{{2}}}}={{({{\bar \beta }}_{{{G}}})}}_{{({{\bar \beta }}_{{{G}}})}{{\ast }}}(\,\bar {\mathcal{\!\!A}}_{{G}})$
the pushforward of the (non-Hausdorff) standard atlas with boundary
 $\,\bar {\mathcal{\!\!A}}_{{G}}$
by
 ${{\bar \beta }}_{{{G}}}$
. Let us see which one is relevant:
Given a traversal
 $(a,b)$
at a vertex
 $v$
of
 $G$
, we consider the path
 \begin{equation*} \gamma \::\:t\in \:]{{-\ell (a)}},{{\ell (b)}}[ \mapsto \left \{ \begin{array}{ll} (a,t+\ell (a)) & \text{ if } t\lt 0 \\ v & \text{if $t=0$} \\ (b,t+\ell (b)) & \text{ if } t\gt 0 \\ \end{array} \right .\in |{G}|. \end{equation*}
We note that the map
 $\tilde \gamma :\:]{{-\ell (a)}},{{\ell (b)}}[\:\to \,\bar {\mathcal{\!\!A}}_{{G}}$
defined by
 $\tilde \gamma (0)=(a,b)$
and
 $\tilde \gamma (t)=\gamma (t)$
for
 $t\not =0$
is a smooth map such that
 $\gamma ={{\bar \beta }}_{{{G}}}\circ \tilde \gamma$
, hence
 $\gamma$
is smooth according to
 ${{\mathcal D}}_{{{2}}}$
. By contrast, as we shall see,
 $\gamma$
is not smooth according to
 ${{\mathcal D}}_{{{{1}}}}$
. Formally speaking, the identity map
 ${id}_{]{{-\ell (a)}},{{\ell (b)}}[}$
is an element of the standard diffeology of
 $]{{-\ell (a)}},{{\ell (b)}}[$
, so if
 $\gamma$
were smooth with respect to
 ${{\mathcal D}}_{{{{1}}}}$
, then it should belong to
 ${{\mathcal D}}_{{{{1}}}}$
; we now prove that it is not the case. Let
 $U$
be an open interval containing
 $0$
and included in
 $]{{-\ell (a)}},{{\ell (b)}}[$
, and let
 $p$
be an element of the standard diffeology of the manifold
 ${{\bar X}}_{{{G}}}$
. By connectedness we have
 $\textit {img}\:(p)\subseteq \{a\} \times [{{0}},{{\ell (a)}}]$
for a certain
 $a\in {{G}}^{{({1})}}$
, and therefore
 $\textit {img}\:(q\circ p)\subseteq \{\textrm {src}(a),\textrm {tgt}(a)\}\:\cup \:]{{0}},{{\ell (a)}}[$
. In particular,
 $q\circ p$
is not the restriction of
 $\gamma$
to
 $U$
, so according to the description of pushforwards,
 $\gamma \not \in {{\mathcal D}}_{{{1}}}$
. The vertices are like impassable frontiers for paths on
 $|{G}|$
that are smooth according to
 ${{\mathcal D}}_{{{1}}}$
, which is certainly not what is expected.
We now check that
 ${{\mathcal D}}_{{{1}}}\subseteq {{\mathcal D}}_{{{2}}}$
(the path
 $\gamma$
witnesses that if
 $G$
has a traversal at a vertex i.e., not an endpoint, then this inclusion is strict). Let
 $U$
be a connected domain and
 $\phi :U\to {{\bar X}}_{{{G}}}$
be a smooth map. There is a (unique) arrow
 $a$
of
 $G$
such that
 $\textit {img}\:(\phi )\subseteq \{a\} \times [{{0}},{{\ell (a)}}]$
, we denote by
 ${{\phi }}_a:U\to \{a\} \times [{{0}},{{\ell (a)}}]$
the corestriction of
 $\phi$
. Given
 ${{\tau }}_{{{1}}}$
,
 ${{\tau }}_{{{2}}}\in \,\bar {\mathcal{\!\!A}}_{{G}}$
traversals at
 $\textrm {src}(a)$
and
 $\textrm {tgt}(a)$
(which may be endpoints of
 $G$
, see Def. 7.2) we have the canonical smooth map
 \begin{equation*} {{\iota }}_a\::\:(a,t)\in \:\{a\} \times [{{0}},{{\ell (a)}}] \mapsto \left \{ \begin{array}{ll} (a,t) & \text{ if } t\in \:]{{0}},{{\ell (a)}}[ \\ {{\tau }}_{{{1}}} & \text{if }t=0 \\ {{\tau }}_{{{2}}} & \text{if } t=\ell (a) \\ \end{array} \right .\in \{{{\tau }}_{{{1}}},{{\tau }}_{{{2}}}\}\:\cup \:]{{0}},{{\ell (a)}}[ \end{equation*}
with
 $\{{{\tau }}_{{{1}}},{{\tau }}_{{{2}}}\}\:\cup \:]{{0}},{{\ell (a)}}[$
submanifold of
 $\,\bar {\mathcal{\!\!A}}_{{G}}$
. The composite of the sequence of smooth maps

is thus a smooth map on
 $\,\bar {\mathcal{\!\!A}}_{{G}}$
, which we denote by
 $\psi$
and which satisfies
 ${{\bar \beta }}_{{{G}}}\circ \psi =q\circ \phi$
. We have proven that the family of parametrizations
 $\{q\circ \phi \mid \phi \text{ smooth and } \textit {dom}\:(\phi ) \text{ connected}\}$
(which generates
 ${{\mathcal D}}_{{{1}}}$
) is contained in
 ${{\mathcal D}}_{{{2}}}$
, therefore
 ${{\mathcal D}}_{{{1}}}\subseteq {{\mathcal D}}_{{{2}}}$
.
Hence the “right” diffeology on
 $|{G}|$
is the pushforward
 ${{({\bar \beta }_{\bar \beta }{G})}}_{{({{\bar \beta }}_{{{G}}})}{{\ast }}}(\,\bar {\mathcal{\!\!A}}_{{G}})$
with
 ${{\bar \beta }}_{{{G}}}$
“the best Hausdorff approximation” under (the topological space of)
 $\,\bar {\mathcal{\!\!A}}_{{G}}$
(Rem. 7.3). So even if we worked with diffeologies to save Hausdorffness, we would not avoid dealing with non-Hausdorff manifolds. Moreover, in view of the importance of tangent vectors in this article, the following issue is to be taken very seriously: «There are many ways to think about tangent spaces, which are equivalent for manifolds but not when applied to diffeological spaces» (Iglesias-Zemmour, Reference Iglesias-Zemmour2013, p. 161).
Diffeological spaces are easy to define, and their category extends that of smooth manifolds in a way that makes standard categorical constructions available. The (probably unavoidable) drawback is that we have no control over the outcomes of such constructions (even if they are applied to manifolds). As a consequence, there are diffeological spaces that have nothing to do with manifolds. The concept of “smooth stratification” overcomes this problem; it was formalized in many different ways, giving rise, for example, to Whitney stratified spaces and conically smooth stratified spaces (Nocera and Volpe, Reference Nocera and Volpe2023, Def. 2.5 and 2.23). Roughly speaking, a space of the first kind consists of a topological space
 $S$
equipped with a partition
 $\mathcal P$
whose elements are topological submanifolds of
 $S$
equipped with a smooth structure. Although the elements of the partition may not be of the same dimension, additional requirements ensure coherence between them: as the author understands (Nocera and Volpe, Reference Nocera and Volpe2023, Def. 2.1 and 2.5) and (Pflaum, Reference Pflaum2001, second paragraph, p. 6),
 $S$
is a subset of an “ambient” smooth manifold
 $M$
such that every subpartition
 $\mathcal P'$
of
 $\mathcal P$
whose union is a topological submanifold of
 $S$
inherits a smooth structure from
 $M$
containing every element of
 $\mathcal P'$
as a smooth submanifold. So providing a topological space with a smooth stratification requires an embedding of it into a smooth manifold. The exact definitions are quite intricate, see in particular (Ayala et al., Reference Ayala, Francis and Tanaka2017, Def. 3.2.21), so we just provide a prototypical example related to graphs. For every
 $\alpha$
,
 $\beta \in {\mathbb{R}}\setminus \{0\}$
, consider the map
 \begin{equation*} {{\theta }}_{{{\alpha \beta }}}\::\:t\in {\mathbb{R}}\quad \mapsto \quad \left \{ \begin{array}{ll} \alpha \exp (\tfrac 1t) & \quad \text{ if } t\lt 0 \\ 0 & \quad \text{ if } t=0 \\ \beta \exp ({-}\tfrac 1t) & \quad \text{ if } t\gt 0 \end{array} \right . \:\:\: \in \:\:\:{\mathbb{R}}. \end{equation*}
The value of the
 $n^{th}$
derivative of
 ${{\theta }}_{{{\alpha \beta }}}$
at
 $t\lt 0$
(resp.
 $t\gt 0$
) is of the form
 $\alpha {{A}}_{{{n}}}(\tfrac 1t)\exp (\tfrac 1t)$
(resp.
 $\beta {{B}}_{{{n}}}({-}\tfrac 1t)\exp ({-}\tfrac 1t)$
) with
 ${{A}}_{{{n}}}$
(resp.
 ${{B}}_{{{n}}}$
) a polynomial only depending on
 $n\in \mathbb{N}$
. According to the well-known properties of the exponential map, we have
 \begin{equation*} \lim _{t\to 0^-}{{A}}_{{{n}}}(\tfrac 1t)\exp (\tfrac 1t) = \lim _{t\to 0^+}{{B}}_{{{n}}}({-}\tfrac 1t)\exp ({-}\tfrac 1t) = 0. \end{equation*}
It follows that the maps
 ${{\gamma }}_{{{\alpha \beta }}}$
defined by
 ${{\gamma }}_{{{\alpha \beta }}}(t)=(t,{{\theta }}_{{{\alpha \beta }}}(t))$
for every
 $t\in {\mathbb{R}}$
are smooth curves on
 ${\mathbb{R}}^2$
(which plays the role of the ambient manifold). Given a finite set
 $\mathcal F\subseteq ({\mathbb{R}}\setminus \{0\})^2$
, the subset
 \begin{equation} S = \bigcup \:\big \{{{\gamma }}_{{{\alpha \beta }}}([{{-1}},{{1}}]))\ \big |\ (\alpha ,\beta )\in \mathcal F\big \} \end{equation}
of
 ${\mathbb{R}}^2$
is a Whitney stratified space (the partition being given by the sets
 $\{{{\gamma }}_{{{\alpha \beta }}}(t)\}$
and
 ${{\gamma }}_{{{\alpha \beta }}}(J)$
for
 $(\alpha ,\beta )\in \mathcal F$
,
 $t\in \{-1,0,1\}$
, and
 $J\in \{]{{-1}},{{0}}[,]{{0}},{{1}}[\}$
): the crucial point is that all the curves
 ${{\gamma }}_{{{\alpha \beta }}}$
, as well as their higher derivatives, coincide at
 $t=0$
.
Now consider the graph
 $G$
whose set of vertices is
 $\{{-n},\ldots ,{m}\}$
for
 $n$
,
 $m\in \mathbb{N}$
fixed, and whose arrows are
 $(\alpha ,0)$
and
 $(0,\beta )$
for
 $\alpha \in \{{-n},\ldots ,{-1}\}$
and
 $\beta \in \{{1},\ldots ,{m}\}$
(the source and the target of
 $(x,y)$
being
 $x$
and
 $y$
respectively). The underlying topological space
 $\textit {Sp}(\mathcal{X}_{{G}})$
of the standard local order on
 $|{G}|$
(Def. 5.11, p. 25) is (canonically) homeomorphic to the subspace
 $S$
of
 ${\mathbb{R}}^2$
given by (21) with
 $\mathcal F=\{{-n},\ldots ,{-1}\} \times \{{1},\ldots ,{m}\}$
. From this example, one conjectures that for every finite graph
 $G$
the space
 $\textit {Sp}(\mathcal{X}_{{G}})$
is homeomorphic to a Whitney stratified subspace
 ${{S}}_{{{G}}}$
of
 ${\mathbb{R}}^n$
(actually
 $n=3$
should be enough). Nevertheless, such an embedding
 $f$
is by no means canonical, and the composite
 $f\circ {{\bar \beta }}_{{{G}}}$
, with
 ${{\bar \beta }}_{{{G}}}$
from Def. 7.2, is a local embedding (it is not global because a non-Hausdorff topological space cannot be embedded into a Hausdorff one). One can deduce, through
 $f\circ {{\bar \beta }}_{{{G}}}$
, the smooth structure of
 ${{S}}_{{{G}}}$
from that of
 $\,\bar {\mathcal{\!\!A}}_{{G}}$
, and vice versa. Due to the technicalities inherent in dealing with Whitney stratified spaces (e.g.,, see (Pflaum, Reference Pflaum2001, §2.1 and §2.2) about tangent bundles and vector fields), it seems to be much easier to work with standard atlases.
In addition to the fact that standard atlases are much more tractable than the corresponding diffeological (resp. Whitney stratified) spaces, we emphasize that, as far as we know, there is no extension of the Lawson correspondence (§5.4, p. 33) to such spaces.
Competing interests
The author declares no competing interests.
Funding statement
This work was partially supported by Agence de l’Innovation de Défense – AID - via Centre Interdisciplinaire d’Etudes pour la Défense et la Sécurité – CIEDS - (project 2021 - FARO).
A. Atlases
The notion of an atlas allows us to apply differential calculus beyond the class of maps between open subsets of (finite dimensional) normed spaces.Footnote 10 We recall some basic definitions without using local coordinates,Footnote 11 and atlases are defined on sets without presupposing any topology (the latter can indeed be recovered from the charts).
A.1 Differential calculus
We assume that differential calculus for smooth maps
 $f:U\to {\mathbb{R}}^m$
with
 $U$
an open subset of
 ${\mathbb{R}}^n$
is known, see (Lang, Reference Lang2002, Chapter I, §2-4) or (Nachbin, Reference Nachbin1981, §13, 14, 16). The derivative of
 $f$
at
 $x\in U$
is a linear map
 ${D{f}}_{{x}}:{\mathbb{R}}^n\to {\mathbb{R}}^m$
which we identify with an
 $m \times n$
matrix with entries in
 $\mathbb{R}$
, that is, an element of
 ${\text{Mat}}_{{n}}^{{m}}({\mathbb{R}})$
. All one really needs here is the derivative of identities and the chain rule
 \begin{equation} D{({{id}}_{U})}_{{x}} = {id}_{{\mathbb{R}}^n} \quad \text{and}\quad D{(g\circ f)}_{{x}} = {D{g}}_{{f x}} \circ {D{f}}_{{x}} \end{equation}
for every element
 $x$
of an open subset
 $U$
of
 ${\mathbb{R}}^n$
. If the map
 $f$
has a smooth inverse
 ${{f}}^{{-1}}$
with
 $fx=y$
, then it is called a smooth diffeomorphism, and the above relations imply that
 \begin{equation} {D{({{f}}^{{-1}})}}_{{y}} = {{\big ({D{f}}_{{x}}\big )}}^{{-1}}. \end{equation}
A translation is a map
 $f$
of the form
 $x\in X\mapsto x+t\in Y$
with
 $X$
and
 $Y$
subsets of
 ${\mathbb{R}}^n$
and
 $t\in {\mathbb{R}}^n$
fixed; if
 $X$
is open then for every
 $x\in X$
we have
 ${D{f}}_{{x}}={id}_{{\mathbb{R}}^n}$
.
A.2 Atlases
A chart of dimension
 $n\in \mathbb{N}$
, or
 $n$
-chart, is a bijection
 $\phi$
whose codomain is an open subset of
 ${\mathbb{R}}^n$
. The
 $n$
-dimensional chart
 $\tilde \phi$
is a subchart of
 $\phi$
, which we denote by
 $\tilde \phi \subseteq \phi$
, when
 $\tilde \phi$
and
 $\phi$
agree on
 $\textit {dom}\:\tilde \phi \subseteq \textit {dom}\:\phi$
(note that we necessarily have
 $\textit {cod}\,\tilde \phi \subseteq \textit {cod}\,\phi$
since
 $\tilde \phi$
is onto). The subcharts of
 $\phi$
are canonically identified with the subsets of
 $\textit {dom}\:\phi$
whose images under
 $\phi$
are open, and therefore with the open subsets of
 $\textit {cod}\,\phi$
. The initial topology on
 $\textit {dom}\:\phi$
is the only one that makes
 $\phi$
a homeomorphism. A subset
 $U\subseteq {\textit {dom}\:\phi }$
is open in the initial topology if, and only if, its image under
 $\phi$
is open. We denote by
 ${{\phi }}_U$
the corresponding subchart of
 $\phi$
.
Definition A.1.
Given the charts
 $\phi$
and
 $\psi$
, a map
 $f$
is said to be smooth around
 $p\in \textit {dom}\: f$
from
 $\phi$
to
 $\psi$
when there are open subsets
 $U$
and
 $V$
of
 $\textit {dom}\:\phi$
and
 $\textit {dom}\:\psi$
such that
 $p\in U\subseteq \textit {dom}\: f$
,
 $f(U)\subseteq V$
, and the composite
 ${{\psi }}_V\circ f\circ {{{{\phi }}_U}}^{{-1}}$
is smooth as a map from
 $\phi U$
to
 $\psi V$
. The sets
 $U$
and
 $V$
are called witnesses of smoothness. The map
 ${{\psi }}_V\circ f\circ {{{{\phi }}_U}}^{{-1}}$
is referred to as the representation of
 $f$
in the charts
 ${{\phi }}_U$
and
 ${{\psi }}_V$
.
Charts are meant to allow differential calculus for mappings whose (co)domains may not be subsets of
 ${\mathbb{R}}^n$
. Indeed, with the denotation from Def. A.1, it is natural to think of the linear map
 ${D{(\psi \circ f\circ {{\phi }}^{-1})}}_{\phi p}$
as the representation of “the” derivative of
 $f$
at
 $p$
(Def. A.14). However, such a representation essentially depends on the charts
 $\phi$
and
 $\psi$
. The concept of an atlas arises from the need to regulate this dependency:
Definition A.2.
The
 $n$
-charts
 $\phi$
and
 $\psi$
are said to be compatible, which we denote by
 $\phi \sim \psi$
, when:
-
i) the intersection
$U=\textit {dom}\:\phi \cap \textit {dom}\:\psi$
is open in both
$\textit {dom}\:\phi$
and
$\textit {dom}\:\psi$
, and
-
ii) the composites
${{\phi }}_{{{U}}}\circ {{{{\psi }}_{{{U}}}}}^{{-1}}$
and
${{\psi }}_U\circ {{{{\phi }}_U}}^{{-1}}$
, which we call transition maps, are smooth.


Following the common usage, we “forget” the subscript
 $U$
and just write
 $\phi \circ {{\psi }}^{{-1}}$
and
 $\psi \circ {{\phi }}^{{-1}}$
instead of
 ${{\phi }}_{{{U}}}\circ {{{{\psi }}_{{{U}}}}}^{{-1}}$
and
 ${{\psi }}_U\circ {{{{\phi }}_U}}^{{-1}}$
.
Remark A.3.
With the notation from Def. A.2
, for every
 $X\subseteq U$
, if
 ${{\phi }}_UX$
is open in
 ${\mathbb{R}}^{n}$
, then so is
 ${{\psi }}_UX$
because we have
 ${{\psi }}_UX=({{\psi }}_U\circ {{{{\phi }}_U}}^{{-1}})({{\phi }}_UX)$
and
 ${{\psi }}_U\circ {{{{\phi }}_U}}^{{-1}}$
is a diffeomorphism, so the inverse mapping theorem applies (Lang, Reference Lang2002
, Thm. 5.2, p. 13). Consequently, the charts
 ${{\phi }}_U$
and
 ${{\psi }}_U$
induce the same topology on
 $U$
, so it suffices to require that
 $U$
is open in
 $\textit {dom}\:\phi$
(resp.
 $\textit {dom}\:\psi$
) in the first point of Def. A.2
.
We follow (Hicks, Reference Hicks1965, p. 2), (Marsden et al., Reference Marsden, Ratiu and Abraham1988, p. 142), and (Lang, Reference Lang1999, p. 22):
Definition A.4.
An atlas is a collection
 $\mathcal{A}_{{}}$
of pairwise compatible charts, its underlying set
 $|{\mathcal{A}_{{}}}|$
is the union
 $ \bigcup \big \{\textit {dom}\:\phi \ \big |\ \phi \in \mathcal{A}_{{}}\big \}$
. The dimension of
 $\mathcal{A}_{{}}$
is the one common to all its charts.
Definition A.5.
Given the atlases
 $\mathcal{A}_{{}}$
and
 $\mathcal{B}_{{}}$
, a map
 $f:|\mathcal{A}_{{}}|\to |\mathcal{B}_{{}}|$
is said to be smooth around
 $p\in |\mathcal{A}_{{}}|$
when there exist two charts
 $\phi \in \mathcal{A}_{{}}$
and
 $\psi \in \mathcal{B}_{{}}$
such that
 $f$
is smooth around
 $p$
from
 $\phi$
to
 $\psi$
(Def. A.1). It is said to be smooth when it is so around every point of
 $\mathcal{A}_{{}}$
. Smooth maps are the morphisms of the category of atlases, which we denote by
 $\mathbf{Atl}$
. An isomorphism of
 $\mathbf{Atl}$
is called a smooth diffeomorphism. The Cartesian product of
 $\mathcal{A}_{{}}$
and
 $\mathcal{B}_{{}}$
in
 $\mathbf{Atl}$
is the atlas
 \begin{equation*} \mathcal{A}_{{}} \times \mathcal{B}_{{}} = \big \{\:\phi \times \psi \:\ \big |\ \big \}{\:\phi \in \mathcal{A}_{{}}\:;\:\psi \in \mathcal{B}_{{}}\:}. \end{equation*}
The transition map between the charts
 $\phi \times \psi$
and
 $\phi ' \times \psi '$
of
 $\mathcal{A}_{{}} \times \mathcal{B}_{{}}$
is the product
 $\tau \times \tau '$
of the transition map
 $\tau$
between
 $\phi$
and
 $\phi '$
and the transition map
 $\tau '$
between
 $\psi$
and
 $\psi '$
.
Smoothness around
 $p$
does not depend on the choice of the charts
 $\phi$
and
 $\psi$
:
Lemma A.6.
Suppose that
 ${{\phi }}_{{{0}}}\sim {{\phi }}_{{{1}}}$
and
 ${{\psi }}_{{{0}}}\sim {{\psi }}_{{{1}}}$
. Let
 $f$
be a map such that
 $\textit {dom}\:{{\phi }}_{{{0}}}\cap \textit {dom}\:{{\phi }}_{{{1}}}\subseteq \textit {dom}\: f$
and
 $f(\textit {dom}\:{{\phi }}_{{{0}}}\cap \textit {dom}\:{{\phi }}_{{{1}}})\subseteq \textit {dom}\:{{\psi }}_{{{0}}}\cap \textit {dom}\:{{\psi }}_{{{1}}}$
. Given any
 $p\in \textit {dom}\:{{\phi }}_{{{0}}}\cap \textit {dom}\:{{\phi }}_{{{1}}}$
, the map
 $f$
is smooth around
 $p$
from
 ${{\phi }}_{{{0}}}$
to
 ${{\psi }}_{{{0}}}$
if, and only if, so it is from
 ${{\phi }}_{{{1}}}$
to
 ${{\psi }}_{{{1}}}$
. In particular we have
 \begin{equation*} \begin{array}{lcl} {{\psi }}_{{{1}}}\circ f\circ {{{{\phi }}_{{{1}}}}}^{{-1}} & = & ({{\psi }}_{{{1}}}\circ {{{{\psi }}_{{{0}}}}}^{{-1}})\circ ({{\psi }}_{{{0}}}\circ f\circ {{{{\phi }}_{{{0}}}}}^{{-1}})\circ {{({{\phi }}_{{{1}}}\circ {{{{\phi }}_{{{0}}}}}^{{-1}})}}^{{-1}}\\ \end{array} \end{equation*}
being understood that the
 ${{\phi }}_i$
’s and the
 ${{\psi }}_i$
’s in the above equation are subcharts of
 ${{\phi }}_i$
and
 ${{\psi }}_i$
whose domains respectively contain
 $p$
and
 $f(p)$
.
Example A.7.
Any open subset
 $U$
of
 ${\mathbb{R}}^n$
is equipped with the atlas
 $\{{{id}}_U\}$
. For any chart
 $\phi$
, the one element set
 $\{\phi \}$
is an atlas, and
 $\phi$
induces a smooth map from
 $\{\phi \}$
to
 $\{{{id}}_{{{\textit {cod}\,\phi }}}\}$
. A curve is a smooth map defined on an open interval of
 $\mathbb{R}$
. A path on an atlas
 $\mathcal{A}_{{}}$
is said to be smooth when it is the restriction of a curve on
 $\mathcal{A}_{{}}$
. A piecewise smooth path on
 $\mathcal{A}_{{}}$
is a concatenation of smooth paths.
Two atlases with the same underlying set are said to be equivalent when their union is still an atlas. A manifold is an equivalence class of atlases.
Definition A.8.
The topology of the atlas
 $\mathcal{A}_{{}}$
is the coarsest one in which
 $\textit {dom}\:(\phi )$
(with the initial topology) is an open subspace for every
 $\phi \in \mathcal{A}_{{}}$
.
Thus every chart of
 $\mathcal{A}_{{}}$
is a homeomorphism. As in (Hicks, Reference Hicks1965, p. 3) and (Lang, Reference Lang1999, Chap. II), we do not require the topology of an atlas to be Hausdorff; yet we have:
Lemma A.9. (Gauld, Reference Gauld2014, Prop. 9.2, p. 153). The topology of any atlas is
 ${{T}}_{{{1}}}$
.
A.3 Tangent bundles and vector fields
A.3.1 Tangent vectors
Let
 $\mathcal{A}_{{}}$
be an atlas of dimension
 $n$
. Given
 $\phi$
,
 $\psi \in \mathcal{A}_{{}}$
,
 $p\in \textit {dom}\:(\phi )$
,
 $q\in \textit {dom}\:(\psi )$
, and
 $a$
,
 $b\in {\mathbb{R}}^n$
, we write
 $(p,\phi ,a)\sim (q,\psi ,b)$
when
 $p=q$
and
 ${D{(\psi \circ {{{\phi }}^{{-1}}})}}_{{{\phi p}}}a=b$
. This makes sense because the elements of
 $\mathcal{A}_{{}}$
are pairwise compatible. The relation
 $\sim$
is reflexive, transitive, and symmetric as a consequence of (22) and (23), p. 49. We follow (Hirsch, Reference Hirsch1976, pp. 16–17):
Definition A.10.
The tangent vectors of
 $\mathcal{A}_{{}}$
are the elements of the quotient
 \begin{equation*} T\mathcal{A}_{{}} = \big \{(p,\phi ,a)\ \big |\ \big \}{\phi \in \mathcal{A}_{{}}, p\in dom\:\phi , \text{ and } a\in {\mathbb{R}}^n} \:/\:\sim \end{equation*}
All the tuples contained in
 $v\in T\mathcal{A}_{{}}$
have the same first component
 $p$
, we say that
 $v$
is a tangent vector at
 $p$
, or that
 $p$
is the attachment point of
 $v$
. We denote by
 $T_{p}\mathcal{A}_{{}}$
the set of all such vectors.
Example A.11.
Following Ex. A.7
, we can suppose that the set of tangent vectors of a single-element atlas
 $\{\phi \}$
is
 $\textit {dom}\:\phi \times {{\mathbb{R}}}^{{\mathbb{R}} }n$
, with
 $n$
the dimension of the chart
 $\phi$
.
For every
 $\phi \in \mathcal{A}_{{}}$
,
 $p\in \textit {dom}\:(\phi )$
, and
 $v\in T_{p}\mathcal{A}_{{}}$
, there is a unique
 ${{[[{{v}}]]}}_{{{p}}}^{{{\phi }}}\in {\mathbb{R}}^n$
such that
 $v$
is the equivalence class of the tuple
 $(p,\phi ,{{[[{{v}}]]}}_{{{p}}}^{{{\phi }}})$
(because every mapping
 ${D{(\psi \circ {{{\phi }}^{{-1}}})}}_{{{\phi p}}}$
with
 $\phi$
,
 $\psi \in \mathcal{A}_{{}}$
and
 $p\in \textit {dom}\:\phi \cap \textit {dom}\:\psi$
, is a bijection). By definition of the relation
 $\sim$
, we have
 \begin{equation} {{[[{{v}}]]}}_{{{p}}}^{{{\psi }}} = \big ({D{(\psi \circ {{\phi }}^{{-1}})}}_{{\phi p}}\big ) {{[[{{v}}]]}}_{{{p}}}^{{{\phi }}} \end{equation}
for every
 $\psi \in \mathcal{A}_{{}}$
with
 $p\in \textit {dom}\:\psi$
.
A.3.2 Tangent spaces
We transfer the (topological) real vector space structure of
 ${\mathbb{R}}^n$
to
 $T_{p}\mathcal{A}_{{}}$
in the obvious way: the linear combination
 $u+\lambda v$
in
 $T_{p}\mathcal{A}_{{}}$
is characterized by the equality
 \begin{equation*} {{[[{{u+\lambda v}}]]}}_{{{p}}}^{{{\phi }}} = {{[[{{u}}]]}}_{{{p}}}^{{{\phi }}} + \lambda {{[[{{v}}]]}}_{{{p}}}^{{{\phi }}}. \end{equation*}
It does not depend on
 $\phi$
because we have the relation (24) and the map
 ${D{(\psi \circ {{\phi }}^{-1})}}_{\phi p}$
is linear. Given
 $n\in \mathbb{N}$
, there is a unique, up to isomorphism, structure of
 $n$
-dimensional Hausdorff topological vector space (tvs for short) (Schaefer and Wolff, Reference Schaefer and Wolff1999, Chap. I, 3.2, 3.4). Hence the following is sound:
Definition A.12.
For any chart
 $\phi$
of
 $\mathcal{A}_{{}}$
with
 $p\in \textit {dom}\:\phi$
, the tangent space of
 $\mathcal{A}_{{}}$
at
 $p$
is
 $T_{p}\mathcal{A}_{{}}$
with the only topological vector space structure that makes the map
 ${{[[{{\_}}]]}}_{{{p}}}^{{{\phi }}}:T_{p}\mathcal{A}_{{}}\to {\mathbb{R}}^n$
an isomorphism.
A.3.3 Tangent bundle
We denote by
 ${{\textit {GL}}}_{{{n}}}({\mathbb{R}})$
the group of
 $n \times n$
invertible matrices with real entries; its underlying set is open in
 ${\text{Mat}}_{{n}}^{{}}({\mathbb{R}})$
equipped with the standard topology.
The set
 $T\mathcal{A}_{{}}$
(Def. A.10) is the underlying set of an atlas: for every
 $\phi \in \mathcal{A}_{{}}$
, one defines the chart
 \begin{equation} T\phi :\:\bigsqcup _{p\in \textit {dom}\:\phi }T_{p}\mathcal{A}_{{}}\quad \to \quad \textit {cod}\,\phi \times {\mathbb{R}}^n \end{equation}
by
 $T\phi (v)=\big (\:\phi p,\:{{[[{{v}}]]}}_{{{p}}}^{{{\phi }}}\:\big )$
for every
 $v\in T_{p}\mathcal{A}_{{}}$
. Given
 $\phi$
,
 $\psi \in \mathcal{A}_{{}}$
, and
 $(x,t)\in \textit {cod}\,\phi \times {\mathbb{R}}^n$
, we have
 $ T\psi \circ {{(T\phi )}}^{{-1}}(x,t) = ((\psi \circ {{\phi }}^{{-1}})x, {D{(\psi \circ {{\phi }}^{{-1}})}}_{{x}}t )$
so the map
 $T\psi \circ {{(T\phi )}}^{{-1}}:\textit {cod}\,\phi \times {\mathbb{R}}^n\to \textit {cod}\,\psi \times {\mathbb{R}}^n$
is smooth because so are the maps
 $ \psi \circ {{\phi }}^{{-1}}:\textit {cod}\,\phi \to \textit {cod}\,\psi$
and
 $ {D{(\psi \circ {{\phi }}^{{-1}})}}_{{}}:\textit {cod}\,\phi \to {{\textit {GL}}}_{{{n}}}({\mathbb{R}})$
. This atlas is called the tangent bundle of
 $\mathcal{A}_{{}}$
; it is also denoted by
 $T\mathcal{A}_{{}}$
. The construction extends to a functor
 $T:\mathbf{Atl}\to \mathbf{Atl}$
. More precisely, if the map
 $f:\mathcal{A}_{{}}\to \mathcal{B}_{{}}$
is smooth, then so is the map
 $Tf:T\mathcal{A}_{{}}\to T\mathcal{B}_{{}}$
defined by
 $Tf(v) = {D{f}}_{{p}}v$
for every
 $v\in T_{p}\mathcal{A}_{{}}$
. Indeed, if
 $T\phi (v)=(x,t)$
then we have
 \begin{equation*} \big (\:T\psi \circ Tf\circ {{(T\phi )}}^{{-1}}\:\big )(x,t) = \big (\:\psi \circ f\circ {{\phi }}^{{-1}}x,\:{D{(\psi \circ f\circ {{\phi }}^{{-1}})}}_{{x}}\cdot t\:\big ), \end{equation*}
and
 ${D{}}_{{}}(\psi \circ f\circ {{\phi }}^{{-1}})$
is smooth as a map from
 $\textit {cod}\,\phi$
to
 ${\text{Mat}}_{{n}}^{{m}}({\mathbb{R}})$
. The tangent bundle functor preserves binary products in the sense that the bijection
 \begin{equation*} \big ((p,q),\phi \times \psi ,(a,b)\big ) \quad \leftrightarrow \quad \big ((p,\phi ,a),(q,\psi ,b)\big ) \end{equation*}
induces a smooth diffeomorphism between
 $T(\mathcal{A}_{{}} \times \mathcal{B}_{{}})$
and
 $T\mathcal{A}_{{}} \times T\mathcal{B}_{{}}$
.
Example A.13.
Following Ex. A.11
, we can suppose that the tangent bundle of a single-element atlas
 $\{\phi \}$
is
 $\{T\phi \}$
with
 $T\phi :(p,v)\in \textit {dom}\:(\phi ) \times {\mathbb{R}}^n\mapsto (\phi (p),v)\in \textit {cod}\,(\phi ) \times {\mathbb{R}}^n$
.
A.3.4 Derivative of a smooth map.
Given a smooth map
 $f:\mathcal{A}_{{}}\to \mathcal{B}_{{}}$
(Def. A.5) and the charts
 $\phi \in \mathcal{A}_{{}}$
and
 $\psi \in \mathcal{B}_{{}}$
with
 $p\in \textit {dom}\:\phi$
and
 $f(p)\in \textit {dom}\:\psi$
, neither the smoothness of
 $f$
around
 $p$
(Def. A.1) nor the validity of the following equality
 \begin{equation} {{[[{{{D{f}}_{p}v}}]]}}_{{{fp}}}^{{{\psi }}} = {D{(\psi \circ f\circ {{\phi }}^{-1})}}_{\phi p} {{[[{{v}}]]}}_{{{p}}}^{{{\phi }}} \end{equation}
depend on
 $\phi$
and
 $\psi$
: it suffices to apply i) the chain rule (§A.1(22)) to the formula from Lem. A.6, and ii) the relation (24). Hence the following definition is sound:
Definition A.14.
The derivative of
 $f$
at
 $p$
is the only map
 ${D{f}}_{{p}}:T_{p}\mathcal{A}_{{}}\to T_{fp}\mathcal{B}_{{}}$
satisfying the equality (
26
) for every
 $v\in T_{p}\mathcal{A}_{{}}$
. The map
 ${D{f}}_{{p}}$
is linear because so are the mappings
 ${{[[{{\_}}]]}}_{{{p}}}^{{{\phi }}}$
,
 ${{[[{{\_}}]]}}_{{{fp}}}^{{{\psi }}}$
, and
 ${D{(\psi \circ f\circ {{\phi }}^{{-1}})}}_{{\phi p}}$
, see §
A.1
and Def. A.12
. The map
 ${D{(\psi \circ f\circ {{\phi }}^{-1})}}_{\phi p}$
is called the representation of
 ${D{f}}_{p}$
in the charts
 $\phi$
and
 $\psi$
, it is denoted by
 ${{[[{{{D{f}}_{p}}}]]}}_{{{\phi }}}^{{\psi }}$
. (We switch from a representation of
 ${D{f}}_{p}$
to another by applying the chain rule (§
A.1
(
22
)) to the formula from Lem. A.6.)
A.3.5 Vector fields and parallelizations
The projection
 $\pi :T\mathcal{A}_{{}}\to \mathcal{A}_{{}}$
sends every tangent vector to its attachment point; it is smooth because its local representation in the charts
 $T\phi$
and
 $\phi$
, see (25), is the projection
 $\textit {cod}\,\phi \times {\mathbb{R}}^n\to \textit {cod}\,\phi$
. A vector field over
 $\mathcal{A}_{{}}$
is a section of
 $\pi$
, that is, a smooth map
 $f:\mathcal{A}_{{}}\to T\mathcal{A}_{{}}$
such that
 $\pi \circ f={id}$
. A parallelization of
 $\mathcal{A}_{{}}$
is a tuple
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
of vector fields over
 $\mathcal{A}_{{}}$
such that
 $({f}_{1}({{p}}){,}\ldots {,}{f}_{{n}}({{p}}))$
is a vector basis of
 $T_{p}\mathcal{A}_{{}}$
for every
 $p\in \mathcal{A}_{{}}$
.
Remark A.15.
For every parallelization
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
of
 $\mathcal{A}_{{}}$
, we have the smooth diffeomorphism
 \begin{equation*} \big (\:p,\:({{a}}_{{1},\ldots ,{{a}}_{n}})\:\big )\:\:\in \:\:\mathcal{A}_{{}} \times {\mathbb{R}}^n\:\qquad \mapsto \qquad \sum _{i=1}^{n}{{a}}_{{{i}}}{{f}}_{{{i}}}(p)\:\:\in \:\:T\mathcal{A}_{{}}. \end{equation*}
Conversely, from any smooth diffeomorphism
 $\Pi :\mathcal{A}_{{}} \times {\mathbb{R}}^n\to T\mathcal{A}_{{}}$
one recovers a parallelization of
 $\mathcal{A}_{{}}$
by putting
 $ {{f}}_{{{i}}} = \Pi \circ \big (p\mapsto (p,{{e}}_{{{i}}})\big )$
with
 $p\in \mathcal{A}_{{}}$
and
 ${{e}}_{{{i}}}$
denoting the
 $i^{th}$
canonical vector of
 ${\mathbb{R}}^n$
.
Example A.16.
Following Ex. A.13
, a parallelization of a single-element
 $n$
-dimensional atlas
 $\{\phi \}$
is given by the tuple
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
with
 ${{f}}_{{{i}}}(p)=(p,{{e}}_{{{i}}})$
and
 ${{e}}_{{{i}}}$
the
 $i^{th}$
canonical vector of
 ${\mathbb{R}}^n$
.
Remark A.17.
If
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
and
 $({{g}}_{{1},\ldots ,{{g}}_{m}})$
are parallelizations of
 $\mathcal{A}_{{}}$
and
 $\mathcal{B}_{{}}$
, then
 $({{f}}_{{1},\ldots ,{{f}}_{n}},{{g}}_{{1},\ldots ,{{g}}_{m}})$
is a parallelization of
 $\mathcal{A}_{{}} \times \mathcal{B}_{{}}$
.
B. Length metrics
Remark B.1.
Let
 $\alpha$
and
 $\beta$
be two arcs with the same image and the same starting point (p. 14). Denote by
 $\tilde \alpha$
and
 $\tilde \beta$
the homeomorphisms induced by
 $\alpha$
and
 $\beta$
on their common image. Then
 $\theta ={{\tilde \beta }}^{{-1}}\circ \tilde \alpha$
is a reparametrization (p. 14) such that
 $\alpha =\beta \circ \theta$
. The case where
 $\alpha$
and
 $\beta$
are mere paths is studied in (Fahrenberg and Raussen (Reference Fahrenberg and Raussen2007)).
Lemma B.2.
For every path
 $\gamma$
from
 $p$
to
 $q$
(with
 $p\not =q$
) on a Hausdorff space
 $X$
, there exists an increasing map
 $j:[0,1]\to \textit {dom}\:(\gamma )$
such that
 $\gamma \circ j$
is an arc from
 $p$
to
 $q$
, and
 $j$
is continuous if, and only if,
 $\gamma$
is an arc (p. 14). Moreover, we can require that
 $j$
be left-continuous with
 $j(0)=\min (\textit {dom}\:(\gamma ))$
, or that
 $j$
be right-continuous with
 $j(1)=\max (\textit {dom}\:(\gamma ))$
.
Proof.
Following (Brazas (Reference Brazas2024)), we have an arc
 $\alpha :[0,1]\to X$
and a non-decreasing surjection
 $f:\textit {dom}\:(\gamma )\to [0,1]$
such that
 $\alpha \circ f=\tilde \gamma$
with
 $\tilde \gamma :\textit {dom}\:(\gamma )\to X$
the path that is constant on
 ${{f}}^{{-1}}\{u\}$
for every
 $u\in [0,1]$
and such that
 $\gamma (t)=\tilde \gamma (t)$
for every
 $t\in \textit {dom}\:(\gamma )\setminus U$
with
 $U$
the union of the interiors of the sets
 ${{f}}^{{-1}}\{u\}$
for
 $u\in [0,1]$
. The map
 $j:[0,1]\to \textit {dom}\:(\gamma )$
defined by
 $j(u)=\min {{f}}^{{-1}}\{u\}$
is left-continuous and satisfies
 $j(0)=\min (\textit {dom}\:(\gamma ))$
,
 $f\circ j={id}_{[0,1]}$
, and
 $\tilde \gamma \circ j=\gamma \circ j$
; it follows that
 $\alpha =\gamma \circ j$
. We could have taken
 $j(u)=\max {{f}}^{{-1}}\{u\}$
to obtain a right-continuous map such that
 $j(1)=\max (\textit {dom}\:(\gamma ))$
.
The Hausdorff property cannot be omitted: suppose that
 $G$
is the graph from Figure 3 (p. 10) and that
 $\|{G}\|$
is equipped with the topology of the standard atlas of
 $G$
(Def. 3.3). Let
 $\gamma$
be a path on
 $\|{G}\|$
from
 $(b,t)$
to
 $(c,t')$
. By a connectedness argument
 $\gamma$
visits some point
 $(a,{{t}}{''})$
, so we can split
 $\gamma$
as a concatenation
 ${{\gamma }}_1\cdot {{\gamma }}_2$
with
 ${{\gamma }}_{{{1}}}$
ending at
 $(a,{{t}}{''})$
. Still by connectedness, both
 ${{\gamma }}_{{{1}}}$
and
 ${{\gamma }}_{{{2}}}$
cover the subset
 $\{a\} \times ]{{{{t}}{''}}},{{1}}[$
of
 $\|{G}\|$
, so
 $\gamma$
is not one-to-one.
Remark B.3. A path on a Hausdorff space preserves closures. An arc on a Hausdorff space induces a homeomorphism on its image (Gauld, Reference Gauld1982 , Thm. 6, p. 32).
B.1 Metrics and pseudometrics
A pseudometric on a set
 $M$
is a map
 $d:M \times M\to \mathbb{R}_{{+}}\cup \{\infty \}$
such that
 $d(x,x)=0$
,
 $d(x,y)=d(y,x)$
, and
 $d(x,z)\leqslant d(x,y)+d(y,z)$
for all
 $x$
,
 $y$
, and
 $z\in M$
. It is a metric when
 $d(x,y)=0$
implies that
 $x=y$
. A (pseudo)metric space is a set equipped with a (pseudo)metric; it comes with a topology whose open sets are unions of open balls, namely the sets of the form
 $ \{\:p\in M\mid d(p,c)\lt r\:\}$
with
 $r\gt 0$
and
 $c\in M$
. The open
 $r$
-neighborhood of
 $X\subseteq M$
is the union of the open balls of radius
 $r$
centered at some point of
 $X$
.
Remark B.4.
Any path
 $\gamma$
on a pseudometric space
 $(M,d)$
is uniformly continuous, that is, for every
 $\varepsilon \gt 0$
, there exists
 $\delta \gt 0$
such that
 $|t-t'|\lt \delta$
implies
 $d(\gamma (t),\gamma (t'))\lt \varepsilon$
(Rudin, Reference Rudin1976
, 4.19, p. 91).
Definition B.5.
The length of a path
 $\gamma$
on the (pseudo)metric space
 $(M,d)$
, which we denote by
 $L(\gamma )$
, is defined as the least upper bound of the collection of sums
 \begin{equation*} \sum _{k=1}^nd\big (\gamma ({{t}}_{{{k-1}}}),\gamma ({{t}}_{{{k}}})\big ) \end{equation*}
with
 ${{t}}_{{{0}}}\leqslant \cdots \leqslant {{t}}_{{{n}}}$
a subdivision of
 $[{{a}},{{b}}]$
. We say that
 $\gamma$
is rectifiable when
 $L(\gamma )$
is finite.
Remark B.6 (Bridson and Haefliger (Reference Bridson and Haefliger1999), Prop. 1.20(3), p. 12). Given a concatenation of paths
 ${{\gamma }}_{1}{}\cdots {}{{\gamma }}_{n}$
(p. 7), we have
 $L({{\gamma }}_{1}{}\cdots {}{{\gamma }}_{n})={L}({{\gamma }}_{1}){+}\cdots {+}{L}({{\gamma }}_{n})$
.
Remark B.7.
The length of a path is invariant under weak reparametrization (p. 14): for every path
 $\gamma :[{{a}},{{b}}]\to (M,d)$
and every weak reparametrization
 $\theta :[{{x}},{{y}}]\to [{{a}},{{b}}]$
, both
 $\gamma$
and
 $\gamma \circ \theta$
have the same length (Papadopoulos, Reference Papadopoulos2013
, 1.1.8). For this reason, when
 $\gamma$
is rectifiable, it is often convenient to suppose that
 $\gamma$
is arclength parametrized, that is, for all
 $a\leqslant t\leqslant t'\leqslant b$
, the length of the subpath
 $\gamma _{|_{[{{t}},{{t'}}]}}$
is
 $t'-t$
. Indeed, for any path
 $\gamma$
, there is a unique reparametrization
 $\theta :[{{0}},{{L(\gamma )}}]\to \textit {dom}\:(\gamma )$
such that
 $\gamma \circ \theta$
is arclength parametrized, see (Papadopoulos, Reference Papadopoulos2013
, §1.2) or (Bridson and Haefliger, Reference Bridson and Haefliger1999
, Prop. 1.20(5), p. 13).
Remark B.8.
Suppose that
 $t\leqslant t'$
and
 $\alpha (t)=\alpha (t')$
with
 $\alpha$
an arclength parametrized pseudo-arc. We have
 $t'-t=L({{{\alpha }|}}_{{{{[{{t}}, ]{t'}}}}})$
and
 $\alpha$
constant on
 $[{{t}},{{t'}}]$
. Therefore,
 $t=t'$
and
 $\alpha$
is an arc.
Definition B.9.
Let
 $(M,d)$
be a metric space. The path
 $\gamma :[{{a}},{{b}}]\to M$
is a geodesic when
 $d(\gamma (t),\gamma (t'))=|t-t'|$
for all
 $t$
,
 $t'\in [{{a}},{{b}}]$
. It is a local geodesic when for all
 $t\in [{{a}},{{b}}]$
there exists
 $\varepsilon \gt 0$
such that the restriction of
 $\gamma$
to
 $[{{a}},{{b}}]\cap [{{t-\varepsilon }},{{t+\varepsilon }}]$
is a geodesic. A subset
 $X\subseteq M$
is said to be geodesically convex when for all
 $p$
,
 $q\in X$
there exists a geodesic from
 $p$
to
 $q$
, and no geodesic from
 $p$
to
 $q$
leaves
 $X$
.
Definition B.10.
The length (pseudo)metric
 ${{d}}_{{{L}}}$
associated with
 $d$
is given by
 \begin{equation*} {{d}}_{{{L}}}(p,q) = \inf \big \{L(\gamma )\ \big |\ \big \}{\gamma \text{ path on } M \text{ from } p \text{ to } q}. \end{equation*}
We have
 ${{d}}_{{{L}}}(p,q)=\infty$
when there is no path from
 $p$
to
 $q$
. The inequality
 $d\leqslant {{d}}_{{{L}}}$
is always satisfied: the (pseudo)metric
 $d$
is said to be intrinsic when
 $d={{d}}_{{{L}}}$
.
Note that if
 $d$
is a metric, then so is
 ${{d}}_{{{L}}}$
because
 ${{d}}_{{{L}}}(p,q)=0$
implies
 $d(p,q)=0$
, and therefore
 $p=q$
. The converse is also true: assume that
 ${{d}}_{{{L}}}$
is a metric and
 $d(p,q)=0$
. Any map
 $\gamma :[{{a}},{{b}}]\to M$
whose image is contained in
 $\{p,q\}$
is continuous with respect to the topology induced on
 $M$
by
 $d$
. Moreover, we have
 $L(\gamma )=0$
, therefore,
 ${{d}}_{{{L}}}(p,q)=0$
and
 $p=q$
.
Given the metric spaces
 $({{M}}_{{{i}}},{{d}}_{{{i}}})$
for
 $i\in \{{1},\ldots ,{n}\}$
, there is no preferred metric
 $d$
on the product
 ${{M}}_{1}{ \times }\cdots { \times }{{M}}_{n}$
among those making the projection maps continuous. The
 $1$
-Lipschitz maps are often taken as metric space morphisms, so we require that
 ${{d}}_{{{i}}}({{p}}_{{{i}}},{{q}}_{{{i}}})\leqslant d(p,q)$
for all points
 $p=({{p}}_{{1},\ldots ,{{p}}_{n}})$
and
 $q=({{q}}_{{1},\ldots ,{{q}}_{n}})$
, and all
 $i\in \{{1},\ldots ,{n}\}$
. In the context of this article, it is also desirable for each slice
 $ {{\sigma }}_i\::\: {{M}}_{{{i}}} \: \hookrightarrow \: \{{{p}}_{{{1}}}\} \times \cdots \times \{{{p}}_{{{i-1}}}\} \times {{M}}_{{{i}}} \times \{{{p}}_{{{i+1}}}\} \times \cdots \times \{{{p}}_{{{n}}}\}$
to be an isometry, that is,
 ${{d}}_{{{i}}}(x,y) = d({{\sigma }}_i(x),{{\sigma }}_i(y))$
for all
 $i\in \{{1},\ldots ,{n}\}$
and
 $x$
,
 $y\in {{M}}_{{{i}}}$
. The Euclidean product metric, that is,
 $\sqrt {{{d}}_{{{1}}}^2+\cdots +{{d}}_{{{n}}}^2}$
, is a special instance of an
 $\alpha$
-product metric:
Definition B.11.
For
 $\alpha \in [{{1}},{{\infty }}]$
, we denote by
 ${{|\_|}}_{{{\alpha }}}$
the
 $\alpha$
-norm on
 ${\mathbb{R}}^n$
, that is,
 ${{|t|}}_{{{\alpha }}}=({|{{t}}_{{{1}}}|}^\alpha +\cdots +{|{{t}}_{{{n}}}|}^\alpha )^{\tfrac 1\alpha }$
when
 $\alpha \not =\infty$
and
 ${{|t|}}_{{{\infty }}}=\max \big \{|{{t}}_{{{i}}}|\ \big |\ \big \}{i\in \{{1},\ldots ,{n}\}}$
for every
 $t\in {\mathbb{R}}^n$
; the
 $\alpha$
-product metric is given by
 \begin{equation*} (p,q)\quad \mapsto \quad {{|{{d}}_{{{1}}}({{p}}_{{{1}}},{{q}}_{{{1}}}),\ldots ,{{d}}_{{{n}}}({{p}}_{{{n}}},{{q}}_{{{n}}})|}}_{{|{{d}}_{{{1}}}({{p}}_{{{1}}},{{q}}_{{{1}}}),\ldots ,{{d}}_{{{n}}}({{p}}_{{{n}}},{{q}}_{{{n}}})|}{{\alpha }}}. \end{equation*}
Proposition B.12.
Any finite
 $\alpha$
-product of intrinsic (pseudo)metrics is an intrinsic (pseudo)metric.
Proof.
See (Bridson and Haefliger (Reference Bridson and Haefliger1999), 5.5(1), p. 58) for
 $\alpha \lt \infty$
; the case
 $\alpha =\infty$
just requires to drop the exponent
 $\alpha$
and replace some occurrences of “
 $+$
” by “max.”
B.2 Length of piecewise smooth paths
For every
 $t\in \:]{{a}},{{b}}[$
, the derivative of a smooth path
 $\gamma :[{{a}},{{b}}]\to \mathcal{A}_{{}}$
at
 $t$
, with
 $\mathcal{A}_{{}}$
an atlas, is a linear map
 $D\gamma _{}t:T_t]{{a}},{{b}}[\:\to T_{\gamma (t)}\mathcal{A}_{{}}$
. Hence
 ${D{\gamma }}_{{t}}$
can be identified with the tangent vector
 ${D{\gamma }}_{}t(1)$
, which we denote by
 $\gamma '(t)$
. We obtain a continuous map
 $\gamma ':[{{a}},{{b}}]\to T\mathcal{A}_{{}}$
setting
 $\gamma '(a)=c'(a)$
and
 $\gamma '(b)=c'(b)$
with
 $c$
being any curve extending
 $\gamma$
. Assuming that every tangent space
 $T_{p}\mathcal{A}_{{}}$
of the atlas
 $\mathcal{A}_{{}}$
is equipped with a norm
 ${{|{\_}|}}_{{{p}}}$
in such a way that the map
 $t\to {{|{\gamma '(t)}|}}_{{{\gamma (t)}}}$
is continuous, one defines the length of
 $\gamma$
as the sum of the norms of the speed vectors along
 $\gamma$
: this is the infinitesimal version of Def. B.5. Riemannian metrics (do Carmo, Reference Do Carmo1992, Def 2.1, p. 38) are such structures, nevertheless, they do not fit our needs (§7, Finsler geometry, p. 37).
Definition B.13.
Given a parallelization
 $({{f}}_{{1},\ldots ,{{f}}_{n}})$
of the atlas
 $\mathcal{A}_{{}}$
, and a norm
 ${{|{\_}|}}_{{{\star }}}$
on
 ${\mathbb{R}}^n$
, the mapping
 \begin{equation} v\:\in \:T_{p}\mathcal{A}_{{}}\quad \mapsto \quad {{|(a_1,\ldots ,a_n)|}}_{{{\star }}}\:\in \:\mathbb{R}_{{+}} \end{equation}
with
 $v={{a}}_{{{1}}}{{f}}_{{{1}}}(p)+\cdots +{{a}}_{{{n}}}{{f}}_{{{n}}}(p)$
is a norm on
 $T_p\mathcal{A}_{{}}$
which we still denote by
 ${{|{\_}|}}_{{{\star }}}$
. The length of a smooth path
 $\gamma :[{{x}},{{y}}]\to \mathcal{A}_{{}}$
is defined as
 \begin{equation*} \mathcal L(\gamma ) = \int _{x}^{y}{{|\gamma '(t)|}}_{{{\star }}}\: dt\:. \end{equation*}
The length of a piecewise smooth path
 ${{\gamma }}_{k}\cdots {k}{{\gamma }}_{1}{}$
is
 ${\mathcal L}({{\gamma }}_{1}){+}\cdots {+}{\mathcal L}({{\gamma }}_{k})$
. The distance between two points
 $p$
and
 $q$
of
 $\mathcal{A}_{{}}$
, which we denote by
 ${{d}}_{{{\mathcal{A}_{{}}}}}(p,q)$
, is then defined as the infimum of
 $\mathcal L(\gamma )$
for
 $\gamma$
(piecewise) smooth path from
 $p$
to
 $q$
.
One can indifferently consider smooth or piecewise smooth paths in the above definition. Indeed, for every piecewise smooth path
 $\gamma$
, one has a finite set
 $F\subseteq \textit {dom}\:\gamma$
such that
 $\gamma '(t)$
exist for all
 $t\not \in F$
. If
 $\theta :[{{a}},{{b}}]\to [{{a}},{{b}}]$
is a non-decreasing surjective smooth path whose derivatives
 ${{D}}^{{({k})}}\theta$
vanish at each point of
 $F$
and at every order
 $k\geqslant 1$
, then the composite
 $\gamma \circ \theta$
is a smooth path. By a mere change of variable, we have
 $L(\gamma )=L(\gamma \circ \theta )$
. The map
 $\theta$
is obtained, for example, as
 \begin{equation*} t\quad \mapsto \quad a+M\int _a^t\Big (1-\sum _{x\in F}\lambda _x\Big ) \end{equation*}
with
 $\{\lambda _x:{\mathbb{R}}\to [0,1]\mid x\in F\}$
a family of bump functions (Hirsch, Reference Hirsch1976, p. 41, 42) such that
 $\lambda _{x}(x)=1$
,
 ${{D}}^{{({k})}}\lambda _x(x)=0$
at every order
 $k\geqslant 1$
, and
 $\lambda _x\lambda _y=0$
when
 $x\not =y$
. The constant
 $M$
has to be chosen in a way that
 $\theta (b)=b$
, in other words
 \begin{equation*} M = \frac {b-a}S\quad \text{with}\quad S = \int _a^b\Big (1-\sum _{x\in F}\lambda _x\Big ) . \end{equation*}
B.3 Technical facts about metric graphs
In this section,
 $G$
is a graph with a map
 $\ell :{{G}}^{{({1})}}\to [{{R}},{{\infty }}]$
such that
 $R\gt 0$
; the associated metric graph
 $(|{G}|,{{d}}_{{{|{G}|}}})$
is given by Def. 4.13, p. 17. The maps
 ${{\chi }}_a:[{{0}},{{\ell (a)}}]\to |{G}|$
with
 $a$
arrow of
 $G$
, are defined on p. 20 (4).
Lemma B.14.
If
 $I=\:]{{0}},{{\ell (a)}}[$
or if
 $I\subsetneq [{{0}},{{\ell (a)}}]$
is closed, then
 ${{\chi }}_a$
induces a homeomorphism from
 $I$
to
 ${{\chi }}_a(I)$
. If
 $\textrm {src}(a)\not =\textrm {tgt}(a)$
, then
 ${{\chi }}_a$
induces a homeomorphism on its image.
Proof.
Denote by
 ${{\tilde \chi }}_{{{a}}}:\:]{{0}},{{\ell (a)}}[\:\to {{\chi }}_a(]{{0}},{{\ell (a)}}[)$
the bijection induced by
 ${{\chi }}_a$
. The direct image map
 ${{\tilde \chi }}_{{{a}}}^\ast$
induces a bijection from the collection of open subintervals of
 $]{{0}},{{\ell (a)}}[$
to the collection of segments of
 $G$
(Def. 2.8, p. 7) contained in
 ${{\chi }}_a(]{{0}},{{\ell (a)}}[)$
. The former (resp. the latter) is a base of the topology of
 $]{{0}},{{\ell (a)}}[$
(resp.
 ${{\chi }}_a(]{{0}},{{\ell (a)}}[)$
by Rem. 2.9, p. 7). Let
 $I$
be a proper closed subinterval of
 $[{{0}},{{\ell (a)}}]$
. If
 $I\subseteq \:]{{0}},{{\ell (a)}}[$
the preceding case applies. If
 $0\in I$
, then
 $I=[{{0}},{{r}}]$
with
 $r\lt \ell (a)$
because
 $I$
is a proper subset of
 $[{{0}},{{\ell (a)}}]$
. So
 ${{\tilde \chi }}_{{{a}}}:[{{0}},{{r}}]\to {{\chi }}_a([{{0}},{{r}}])$
, the restriction of
 ${{\chi }}_a$
, is a bijection. Moreover,
 ${{\tilde \chi }}_{{{a}}}$
is continuous because so is
 ${{\chi }}_a$
(Rem. 2.9). We conclude that
 ${{\tilde \chi }}_{{{a}}}$
is a homeomorphism by Rem. B.3, which applies because
 $|{G}|$
is Hausdorff (Rem. 2.9).
Lemma B.15.
Any path
 $\gamma$
on
 $|{G}|$
visits finitely many vertices.
Proof.
We recall that
 $\ell \geqslant R$
with
 $R\gt 0$
. The union
 $V$
of stars of radius
 $\tfrac R3$
centered at some vertex of
 $G$
(Def. 2.7, p. 7) does not contain any point of the form
 $(a,{\ell (a)}/2)$
with
 $a\in {{G}}^{{({1})}}$
; such a point is called a middle point. The set
 $U=|{G}|\setminus {{G}}^{{({0})}}$
is an open neighborhood of
 $|{G}|\setminus V$
that contains all the middle points but no vertex of
 $G$
. The family
 $\mathcal{C}$
made of
 $U$
and the stars of radius
 $\tfrac R3$
centered at some vertex of
 $G$
visited by
 $\gamma$
is an open covering of the image of
 $\gamma$
. Suppose that
 $\gamma$
visits at least two vertices. By a connectedness argument,
 $\gamma$
visits at least one middle point. Moreover, the stars of radius
 $\tfrac R3$
are pairwise disjoint. It follows that no strict subfamily of
 $\mathcal{C}$
covers the image of
 $\gamma$
which is compact, so the family
 $\mathcal{C}$
is finite, and
 $\gamma$
visits finitely many vertices of
 $G$
.
Remark B.16.
If the step
 $s={{\chi }}_a\circ \theta$
(Def. 4.3
, p. 14) is written as a concatenation
 ${{s}}_{1}{}\cdots {}{{s}}_{n}$
(p. 7), then we have (up to translation of the domains of definitions of the paths
 ${{s}}_{{{i}}}$
) a subdivision
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{n}$
of
 $\textit {dom}\:(s)$
such that
 $\textit {dom}\:({{s}}_{{{i}}})=[{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}]$
and the restriction of
 $s$
to
 $[{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}]$
coincide with
 ${{s}}_{{{i}}}$
for every
 $i\in \{{1},\ldots ,{n}\}$
. If
 $n=1$
then
 $s={{s}}_{{{1}}}$
; otherwise, each interval
 $[{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}]$
is proper in
 $[{{0}},{{\ell (a)}}]$
, so Lem. B.14 applies and
 ${{s}}_{{{i}}}={{\chi }}_a\circ {{{\theta }|}}_{{{{[{{t_{i-1}}},{{t_i}}]}}}}$
. Since
 $\theta$
is an arc on
 $[{{0}},{{\ell (a)}}]$
, it induces an homeomorphism on its image; in particular, it is either increasing or decreasing. It follows that
 $\theta ({{t}}_{{{i-1}}})\leqslant \theta ({{t}}_{{{i}}})$
for every
 $i\in \{{1},\ldots ,{n}\}$
or
 $\theta ({{t}}_{{{i-1}}})\geqslant \theta ({{t}}_{{{i}}})$
for every
 $i\in \{{1},\ldots ,{n}\}$
. In the first case, we have
 \begin{equation*} |\theta ({{t}}_{{{n}}})-\theta ({{t}}_{{{0}}})| = \theta ({{t}}_{{{n}}})-\theta ({{t}}_{{{0}}}) = \sum _{i=1}^n\theta ({{t}}_{{{i}}})-\theta ({{t}}_{{{i-1}}}) = \sum _{i=1}^n|\theta ({{t}}_{{{i}}})-\theta ({{t}}_{{{i-1}}})| \end{equation*}
the second one being dealt with the same way. We conclude that
 $\ell (s)={\ell }(_{s}){n}\cdots {n}{\ell }(_{1})+$
.
Lemma B.17.
If the concatenations (p. 7) of steps
 ${{s}}_{1}{}\cdots {}{{s}}_{n}$
and
 ${{\tilde s}}_{1}{}\cdots {}{{\tilde s}}_{m}$
are equal, then
 ${\ell }(_{s}){n}\cdots {n}{\ell }(_{1})+={\ell }(_{\tilde s}){m}\cdots {m}{\ell }(_{1})+$
.
Proof.
Let
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{n}$
and
 ${{\tilde t}}_{0}{\lt }\cdots {\lt }{{\tilde t}}_{m}$
with
 $\textit {dom}\:({{s}}_{{{i}}})=[{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}]$
and
 $\textit {dom}\:({{s}}_i)=[{{{{\tilde t}}_{{{i-1}}}}},{{{{\tilde t}}_{{{i}}}}}]$
. Following our notion of concatenation, we have
 $[{{{{t}}_{{{0}}}}},{{{{t}}_{{{n}}}}}]=[{{{{\tilde t}}_{{{0}}}}},{{{{\tilde t}}_{{{m}}}}}]$
. Suppose that
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{n}$
is finer than
 ${{\tilde t}}_{0}{\lt }\cdots {\lt }{{\tilde t}}_{m}$
(otherwise consider a third subdivision i.e., finer than both of them) and conclude by Rem. B.16.
We recall that a path
 $\gamma$
on
 $|{G}|$
is said to be admissible when it can be written as a (finite) concatenation of steps (Def. 4.4, p. 14).
Lemma B.18.
Every arc
 $\alpha$
on
 $|{G}|$
is admissible.
Proof.
The set of vertices visited by
 $\alpha$
is finite (Lem. B.15) and
 $\alpha$
is one-to-one, so the set
 ${{\gamma }}^{{-1}}({{G}}^{{({0})}})$
is finite: let
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{k}$
be its enumeration. Given
 $i\in \{{1},\ldots ,{k}\}$
, the map
 $\theta :\xi \in [{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}]\mapsto {{{{\chi }}_a}}^{{-1}}(\alpha (\xi ))\in [{{0}},{{\ell (a)}}]$
is an arc (Rem. B.3 and Lem. B.14) such that the restriction of
 $\alpha$
to
 $[{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}]$
is
 ${{\chi }}_a\circ \theta$
.
Lemma B.19.
If the image of an arc
 $\alpha$
is contained in the image of an admissible path
 $\gamma$
, then
 $\ell (\alpha )\leqslant \ell (\gamma )$
. Equality holds if, and only if,
 $\gamma$
is an arc and
 $\textit {img}\:(\alpha )=\textit {img}\:(\gamma )$
.
Proof.
We write
 $\gamma$
as a concatenation of steps
 ${{\gamma }}_{1}{}\cdots {}{{\gamma }}_{n}$
. If
 $\alpha$
is reduced to a single step, then we can write it as
 ${{\alpha }}_{1}{}\cdots {}{{\alpha }}_{m}$
so that for every
 $j\in \{{1},\ldots ,{m}\}$
and every
 $i\in \{{1},\ldots ,{n}\}$
, if
 ${{\alpha }}_{{{j}}}$
and
 ${{\gamma }}_{{{i}}}$
are overlapping (Def. 4.3, p. 14), then
 $\textit {img}\:({{\alpha }}_{{{j}}})\subseteq \textit {img}\:({{\gamma }}_{{{i}}})$
; in particular, there is some
 $i\in \{{1},\ldots ,{n}\}$
such that
 $\textit {img}\:({{\alpha }}_{{{j}}})\subseteq \textit {img}\:({{\gamma }}_{{{i}}})$
. As a consequence of Lem. B.18, the same holds for any arc
 $\alpha$
. Hence we have a map
 $f:\{{1},\ldots ,{m}\}\to \{{1},\ldots ,{n}\}$
defined by
 \begin{equation*} f(j) = \min \big \{\:i\in \{{1},\ldots ,{n}\}\ \big |\ \text{img}({{\alpha }}_{{{j}}})\subseteq \text{img}({{\gamma }}_{{{i}}})\:\big \} \end{equation*}
and we observe that
 \begin{equation} \ell (\alpha ) = \sum _{i=1}^{n}\left (\sum _{j\in {{f}}^{{-1}}\{i\}}\ell ({{\alpha }}_{{{j}}})\right ). \end{equation}
For any
 $i\in \{{1},\ldots ,{n}\}$
and any distinct
 $j,j'\in {{f}}^{{-1}}\{i\}$
, the steps
 ${{\alpha }}_{{{j}}}$
and
 ${{\alpha }}_{{{j'}}}$
do not overlap, so we have
 \begin{equation} \sum _{j\in {{f}}^{{-1}}\{i\}}\ell ({{\alpha }}_{{{j}}}) \quad \leqslant \quad \ell ({{\gamma }}_{{{i}}}). \end{equation}
Since
 $\ell (\gamma )=\ell ({{\gamma }}_{{{1}}})+\cdots +\ell ({{\gamma }}_{{{n}}})$
(Def. 4.4, p. 14), we deduce from (28) and (29) that
 $\ell (\alpha ) \leqslant \ell (\gamma )$
. Under the assumption that
 $\gamma$
is an arc such that
 $\textit {img}\:(\alpha )=\textit {img}\:(\gamma )$
, the roles of
 $\alpha$
and
 $\gamma$
can be swapped, so we have
 $\ell (\alpha )=\ell (\gamma )$
.
If the image of
 $\gamma$
strictly contains that of
 $\alpha$
, then some step
 ${{\gamma }}_{{{i}}}$
is not covered by
 $\alpha$
and consequently, we have some index
 $i$
for which the inequality (29) is strict.
Suppose that
 $\gamma$
is not an arc and
 $\textit {img}\:(\alpha )=\textit {img}\:(\gamma )$
. We have a point
 $p\in \textit {img}\:(\gamma )$
such that
 ${{\gamma }}^{{-1}}\{p\}$
is not a singleton, and (a unique)
 $\tau \in \textit {dom}\:(\alpha )$
such that
 $\alpha (\tau )=p$
. Let
 $j\in \{{1},\ldots ,{m}\}$
be such that
 $\tau \in \textit {dom}\:({{\alpha }}_{{{j}}})$
(there are at most two such indices, and they are consecutive). In particular,
 $\textit {img}\:({{\alpha }}_{{{j}}})\subseteq \textit {img}\:({{\gamma }}_{{{k}}})$
with
 $k=f(j)$
, and
 $t\in \textit {dom}\:({{\gamma }}_{{{k}}})$
with
 $t=\min ({{\gamma }}^{{-1}}\{p\})$
. Let
 $t'=\max ({{\gamma }}^{{-1}}\{p\})$
, we have
 $t\lt t'$
and
 $\gamma (t')=\gamma (t)$
. Denote by
 $a$
the support of the step
 ${{\gamma }}_{{{k}}}$
(Def. 4.3, p. 14). If the image of
 ${{\chi }}_a$
is covered by
 $\gamma$
, then it is also covered by the arc
 $\alpha$
, so
 $\textrm {src}(a)\not =\textrm {tgt}(a)$
. In any case, the step
 ${{\gamma }}_{{{k}}}$
is an arc (Lem. B.14), so
 $t'\not \in \textit {dom}\:({{\gamma }}_k)$
. Let
 $k'\in \{{1},\ldots ,{n}\}$
such that
 $t'\in \textit {dom}\:({{\gamma }}_{{{k'}}})$
; one of the steps
 ${{\gamma }}_{{{k'-1}}}$
,
 ${{\gamma }}_{{{k'}}}$
, and
 ${{\gamma }}_{{{k'+1}}}$
is overlapping
 ${{\alpha }}_{{{j}}}$
. Up to renaming, suppose that it is
 ${{\gamma }}_{{{k'}}}$
. We have
 $\textit {img}\:({{\alpha }}_{{{j}}})\subseteq \textit {img}\:({{\gamma }}_{{{k'}}})$
and
 $k\lt k'$
; it follows that
 $j\not \in {{f}}^{{-1}}(\{k'\})$
so the inequality (29) is strict for
 $i=k'$
. Whether we have
 $\textit {img}\:(\alpha )\not =\textit {img}\:(\gamma )$
or
 $\gamma$
not one-to-one, we deduce that
 $\ell (\alpha )\lt \ell (\gamma )$
.
Lemma B.20.
For every admissible path
 $\gamma$
on
 $|{G}|$
, we have
 $L(\gamma )=\ell (\gamma )$
, that is, the length in the sense of Def. B.5 is equal to the length in the sense of Def. 4.4
, p. 14.
Proof.
Given a step
 $s$
, if the subdivision
 ${{t}}_{0}{\lt }\cdots {\lt }{{t}}_{n}$
of
 $\textit {dom}\:(s)$
is fine enough, we have
 $\ell ({{s}}_{{{i}}})\lt \tfrac R2$
with
 ${{s}}_{{{i}}}$
denoting the restriction of
 $s$
to
 $[{{{{t}}_{{{i-1}}}}},{{{{t}}_{{{i}}}}}]$
. It follows that
 ${{d}}_{{{|{G}|}}}(s({{t}}_{{{i}}}),s({{t}}_{{{i-1}}}))\lt \tfrac R2$
(Def. 4.5, p. 15). From Lem. 4.10 (p. 16), we deduce that
 $\ell ({{s}}_{{{i}}})={{d}}_{{{|{G}|}}}(s({{t}}_{{{i}}}),s({{t}}_{{{i-1}}}))$
, and therefore
 \begin{equation*} \sum _{i=1}^n{{d}}_{{{|{G}|}}}(s({{t}}_{{{i}}}),s({{t}}_{{{i-1}}})) = \sum _{i=1}^n\ell ({{s}}_{{{i}}}) = \ell (s), \end{equation*}
the second equality being given by Rem. B.16. Hence
 $L(s)=\ell (s)$
. Given a concatenation of steps
 ${{\gamma }}_{n}\cdots {n}{{\gamma }}_{1}{}$
, we have (the last equality being given by Def. 4.4)
 \begin{equation*} L({{\gamma }}_{n}\cdots {n}{{\gamma }}_{1}{}) = \sum _{i=1}^nL({{\gamma }}_i) = \sum _{i=1}^n\ell ({{\gamma }}_i) = \ell ({{\gamma }}_{n}\cdots {n}{{\gamma }}_{1}{}). \end{equation*}
B.3.1 The length metric is approximated by arcs
Lemma B.21.
For every path
 $\gamma$
from
 $p$
to
 $q$
on the metric graph of
 $G$
, there exists an arc
 $\alpha$
from
 $p$
to
 $q$
such that
 $\textit {img}\:(\alpha )\subseteq \textit {img}\:(\gamma )$
,
 $L(\alpha )\leqslant L(\gamma )$
, and
 $\gamma$
is a pseudo-arc if, and only if,
 $L(\alpha )=L(\gamma )$
.
Proof.
Let
 $\gamma$
be a path on
 $|{G}|$
from
 $p$
to
 $q$
. The metric graph of
 $G$
is a metric space (Def. 4.13, p. 17) so its topology is Hausdorff. As a consequence, we have an increasing left-continuous map
 $j:[0,1]\to \textit {dom}\:(\gamma )$
such that
 $\alpha =\gamma \circ j$
is an arc from
 $p$
to
 $q$
and
 $j(0)=\min (\textit {dom}\:(\gamma ))$
(Lem. B.2). Moreover,
 $\alpha$
is admissible (Lem. B.18) so it is rectifiable (Lem. B.20). If
 $\gamma$
is not rectifiable, then
 $L(\gamma )=\infty \gt L(\alpha )$
. Otherwise, we can suppose that
 $\gamma$
is arclength parametrized (Rem. B.7). Given a subdivision
 ${{\tau }}_{0}{\lt }\cdots {\lt }{{\tau }}_{n}$
of
 $[0,1]$
, the subdivision
 ${j}({{\tau }}_{0}){\lt }\cdots {\lt }{j}({{\tau }}_{n})$
of
 $\textit {dom}\:(\gamma )$
satisfies
 $\gamma (j({{\tau }}_i))=\alpha ({{\tau }}_i)$
. It follows that
 $L(\alpha )\leqslant L(\gamma )$
.
If
 $\gamma$
is a pseudo-arc, then it is an arc because
 $\gamma$
is arclength parametrized (Rem. B.8). It follows that
 $j$
is continuous (Lem. B.2). Moreover, we have
 $\gamma \circ j(1)=\alpha (1)=q$
. Since
 $\gamma$
is one-to-one we have
 $j(1)=\max (\textit {dom}\:(\gamma ))$
. Hence
 $j$
is a reparametrization (p. 4), and
 $L(\alpha )=L(\gamma )$
(Rem. B.7).
If
 $\gamma$
is not an arc, then
 $j$
is not right-continuous at some
 $\tau \in [{{0}},{{1}}[$
(Lem. B.2), that is
 $ r = \inf \big \{j(\tau +\varepsilon )-j(\tau )\ \big |\ \big \}{0\lt \varepsilon \lt 1-\tau } \gt 0$
. Let
 $t=j(\tau )$
and
 $t'=t+r$
, we have
 $\gamma (t)=\gamma (t')$
because
 $\gamma \circ j$
is continuous (in particular the subpath
 ${{{\gamma }|}}_{{{{[{{t}},{{t'}}]}}}}$
is a loop). From any subdivision
 ${{\tau }}_{0}{\lt }\cdots {\lt }{{\tau }}_{n}$
of
 $[0,1]$
, we deduce the subdivision
 $ {j}({{\tau }}_{0}){\lt }\cdots {\lt }{j}({{\tau }}_{k})\leqslant t \lt t' \leqslant {j}({{\tau }}_{k+1}){\lt }\cdots {\lt }{j}({{\tau }}_{n})$
of
 $\textit {dom}\:(\gamma )$
. In particular,
 ${j}({{\tau }}_{0}){\lt }\cdots {\lt }{j}({{\tau }}_{k})\leqslant t$
and
 $t'\leqslant {j}({{\tau }}_{k+1}){\lt }\cdots {\lt }{j}({{\tau }}_{n})$
are subdivisions of
 $[{{0}},{{t}}]$
and
 $[{{t'}},{{1}}]$
, and we have
 $d(\gamma (t'),\gamma (t))=0$
. It follows that
 $L(\alpha )\leqslant L({{{\gamma }|}}_{{{{[{{0}},{{t}}]}}}})+L({{{\gamma }|}}_{{{{[{{t'}},{{1}}]}}}})$
, therefore,
 $L(\alpha ) \lt L(\gamma )$
because
 $L(\gamma )=L({{{\gamma }|}}_{{{{[{{0}},{{t}}]}}}})+L({{{\gamma }|}}_{{{{[{{t}},{{t'}}]}}}})+L({{{\gamma }|}}_{{{{[{{t'}},{{1}}]}}}})$
(Rem. B.6), and
 $L({{{\gamma }|}}_{{{{[{{t}},{{t'}}]}}}})=r\gt 0$
since
 $\gamma$
is arclength parametrized.
B.3.2 Geodesically convex balls
Open balls with “small” radii are geodesically convex (Def. B.9):
Proposition B.22.
Every open ball
 $B$
of
 $|{G}|$
with radius
 $r\leqslant \tfrac R4$
is geodesically convex. If the center of
 $B$
is an isolated vertex, then
 $B$
is a singleton; otherwise, the center is
 ${{\chi }}_c(\rho )$
for some arrow
 $c$
and
 $\rho \in [{{0}},{{\ell (c)}}]$
, and
 \begin{equation} B= \left \{ \begin{array}{ll} \{c\} \times ]{{\rho -r}},{{\rho +r}}[ & \text{if}\ r\leqslant \rho \leqslant \ell (c)-r, \\[1,5mm] S(\textrm {src}\ c,r-\rho )\:\cup \:\{c\} \times ]{{0}},{{\rho +r}}[ & \text{if }r\gt \rho , \text{and} \\[1,5mm] \{c\} \times ]{{\rho -r}},{{\ell (c)}}[\:\cup \:S(\textrm {tgt}\ c,\rho +r-\ell (c)) & \text{if}\ \rho +r\gt \ell (c). \end{array} \right . \end{equation}
with
 $S(v,x)$
denoting the star centered at the vertex
 $v$
with radius
 $x$
(Def. 2.7
, p. 7).
Proof.
The case where the center of
 $B$
is an isolated vertex is obvious, so we assume it is not. First, we prove that the right hand part of each equality appearing in (30) is a geodesically convex set. Let
 $p$
and
 $q$
be two distinct points of such a set, which we denote by
 $X$
in the sequel.
If
 $X$
is described by the 1
 $^{\textit {st}}$
case of (30), then given
 $p=(c,s)$
and
 $q=(c,t)$
with
 $s$
,
 $t\in \:]{{\rho -r}},{{\rho +r}}[$
, we have
 $|t-s|\lt 2r\leqslant R/2\leqslant \ell (a)/2$
; so we are in the first case of Lem. 4.10 (p. 16), the step
 $p\to q$
is the unique geodesic from
 $p$
to
 $q$
, and
 $\textit {img}\:(p\to q)\subseteq \{c\} \times ]{{\rho -r}},{{\rho +r}}[$
.
If
 $X$
is described by the 2
 $^{\textit {nd}}$
(resp. 3
 $^{\textit {rd}}$
) case of (30), then it contains a unique vertex
 $v$
, which is the center of the star appearing in this description, that is,
 $v=\textrm {src}\ c$
(resp.
 $v=\textrm {tgt}\ c$
). In particular, the connected components of
 $X\setminus \{v\}$
are of the form
 $\{x\} \times I$
with
 $I$
an open interval of
 $]{{0}},{{\ell (x)}}[$
of length at most
 $2r$
, which is either initial (in which case
 $\textrm {src}\ x=v$
) or final (in which case
 $\textrm {tgt}\ x=v$
). Since
 $p$
and
 $q$
are neighbors (
 ${{d}}_{{{|{G}|}}}(p,q)\lt R/2$
), the shortest path
 $\alpha$
from
 $p={{\chi }}_a(s)$
to
 $q={{\chi }}_b(t)$
is the only admissible path of length
 ${{d}}_{{{|{G}|}}}(p,q)$
up to reparametrization (Lem. 4.10). We have one of the following situations:
-
– There is a connected component
$\{x\} \times I$
of
$X\setminus \{v\}$
such that
$p$
,
$q\in \{v\}\cup \{x\} \times I$
(therefore,
$x\in \{a,b\}$
). Since the length of
$I$
is at most
$2r$
, the arc
$\alpha$
is reduced to the dash
$p\to q$
(Def. 4.7, p. 15) and its image is included in
$\{v\}\cup \{x\} \times I$
. -
– The points
$p$
and
$q$
respectively belong to the connected components
$\{a\} \times I$
and
$\{b\} \times J$
of
$X\setminus \{v\}$
. We observe that
$\text{length}(I)+\text{length}(J)\leqslant 2r$
. If
$a=b$
, then
$I\cap J=\emptyset$
andHence no matter that
\begin{equation*} |t-s| \:\geqslant \: \ell (a)-(\ell (I)+\ell (J)) \:\geqslant \: \ell (a)-2r \:\geqslant \: \ell (a)-\tfrac R2 \:\geqslant \: \tfrac 12\ell (a). \end{equation*}
$a\not =b$
or
$a=b$
, the second item of Lem. 4.10 applies; we deduce that the arc
$\alpha$
is
$p\to v\to q$
and its image is contained in
$(\{a\} \times I)\cup \{v\}\cup (\{b\} \times J)$
.


By Lem. B.21, any geodesic
 $\gamma$
from
 $p$
to
 $q$
is an arc up to reparametrization (p. 4). Therefore,
 $\alpha$
and
 $\gamma$
are equal up to weak reparametrization, and we have, in particular,
 $\textit {img}\:(\gamma )=\textit {img}\:(\alpha )$
. Hence
 $X$
is geodesically convex.
We readily deduce from the definition of
 ${{d}}_{{{|{G}|}}}$
(Def. 4.5, p. 15) that
 $B$
contains
 $X$
, so it remains to check the converse inclusion. Any point
 $p$
of
 $B$
is a neighbor of the center
 $q$
of
 $B$
. Let
 $\alpha$
be the shortest path from
 $p$
to
 $q$
, which is actually an arc (Lem. 4.10), we have
 $L(\alpha )\lt r$
. According to the description of
 $\alpha$
given in Lem. 4.10, we have
 $p={{\chi }}_a(t)$
and
 $q={{\chi }}_c(\rho )$
with
 $t\in [{{0}},{{\ell (a)}}]$
and
 $\rho \in [{{0}},{{\ell (c)}}]$
. We have three cases to deal with according to the inequalities relating
 $r$
and
 $\rho$
.
Suppose that
 $r\leqslant \rho \leqslant \ell (c)-r$
. The length of any path whose image covers
 $\{c\} \times ]{{0}},{{r}}]$
or
 $\{c\} \times [{{\ell (c)-r}},{{\ell (c)}}[$
is at least
 $r$
. Hence the image of
 $\alpha$
is included in
 $\{c\} \times ]{{\rho -r}},{{\rho +r}}[$
.
Now assume that
 $r\gt \rho$
. If
 $p$
and
 $q$
are on the same arrow of
 $|{G}|$
(i.e.
 $a=c$
) then
 $\alpha$
is reduced to the dash
 $p\to q$
whose image is
 ${{\chi }}_c[{{\min (t,\rho )}},{{\max (t,\rho )}}]$
. This latter is included in
 $\{\textrm {src}\ c\}\cup (\{c\} \times ]{{0}},{{\rho +r}}[)$
. If
 $p$
and
 $q$
are not on the same arrow of
 $|{G}|$
(i.e.
 $a\not =c$
), then
 $\alpha$
is
 $p\to v\to q$
with
 $v$
the only vertex of
 $B$
. The length of
 $v\to q$
is
 $\rho$
so the length of
 $p\to v$
is
 ${{d}}_{{{|{G}|}}}(p,q)-\rho \lt r-\rho$
. Moreover,
 $v=\textrm {src}\ c$
because
 $r\lt R\leqslant \ell (c)$
. Hence
 $p\in S(v,r-\rho )$
. The last case is dealt with the same way.
A similar result holds for closed balls with the constraint
 $r\lt \tfrac R4$
and the boundaries in the description (30) adapted accordingly.
Prop. B.22 does not hold for open balls of an
 $\infty$
-product (Def. B.11) of metric graphs: the broken line
 $\gamma$
(on the following picture) is a geodesic of
 ${\mathbb{R}}^2$
(with the maximum metric) joining two points of the ball
 $B$
, namely
 $p$
and
 $q$
, whose image is not contained in
 $B$
.