



1 Introduction
The aim of this paper is to present an exact and explicit (in the Lagrangian labelling variables) solution to a
 $\unicode[STIX]{x1D6FD}$
-plane approximation of the governing equations for geophysical fluid dynamics in the equatorial region, which incorporates both Coriolis and centripetal forces. The resulting solution represents a wave–current interaction, whereby the zonally periodic wave-like term is ‘equatorially trapped’ (it exhibits exponentially strong decay meridionally) and propagates eastwards above a flow which accommodates a constant underlying background current. Geophysical fluid dynamics is the study of fluid motion where the physical scale is such that the effects of the Earth’s rotation play a significant role, and accordingly the full governing equations incorporate both Coriolis and centripetal forces in the Euler equation. These governing equations are applicable for a wide range of oceanic and atmospheric flows (see Vallis Reference Vallis2006; Cushman-Roisin & Beckers Reference Cushman-Roisin and Beckers2011), and due to their complexity and intractability one typically invokes geophysical considerations in order to derive simpler approximate models. In an oceanographic context, centripetal forces are typically neglected as they are relatively much smaller (
 ${\sim}O(\unicode[STIX]{x1D6FA}^{2})$
) than Coriolis terms (
 ${\sim}O(\unicode[STIX]{x1D6FA})$
), where
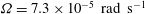 $\unicode[STIX]{x1D6FA}=7.3\times 10^{-5}~\text{rad}~\text{s}^{-1}$
is the (constant) rotational speed of the Earth. While we invoke a
 $\unicode[STIX]{x1D6FD}$
-plane approximation, which is applicable in modelling equatorial flows restricted to regions of relatively small latitudinal variation (to of the order of
 $5^{\circ }$
), in the following we also retain both Coriolis and centripetal forces. Remarkably, centripetal force terms play a central role in facilitating the admission of a wide range of constant underlying currents in the exact solution we present below in (3.1).
The
 $\unicode[STIX]{x1D6FD}$
-plane governing equations we solve, modified to incorporate centripetal terms, were recently derived in Constantin & Johnson (Reference Constantin and Johnson2016) in a different context, whereby the authors established the existence in the equatorial region of exact purely azimuthal solutions to the geophysical governing equations in spherical, cylindrical and
 $\unicode[STIX]{x1D6FD}$
-plane coordinates. The solution (3.1) we present for the modified
 $\unicode[STIX]{x1D6FD}$
-plane corresponds, in the absence of a current, to an azimuthally periodic wave solution. The existence of explicit and exact nonlinear solutions to the standard equatorial
 $\unicode[STIX]{x1D6FD}$
-plane model was first established in Constantin (Reference Constantin2012), and subsequently generalizations of this solution were obtained which modelled a variety of geophysical scenarios (Matioc Reference Matioc2012, Reference Matioc2013; Constantin Reference Constantin2013, Reference Constantin2014; Constantin & Germain Reference Constantin and Germain2013; Hsu Reference Hsu2014; Ionescu-Kruse Reference Ionescu-Kruse2015). In particular, it was shown in Henry (Reference Henry2013) that the solution in Constantin (Reference Constantin2012) could be suitably modified to admit a constant following current of any magnitude, whereas the range of admissible adverse currents is greatly restricted. In the main result of this paper, presented in Proposition 1 below, we show that this restriction on the magnitude of adverse currents is greatly alleviated by the presence of centripetal forces, and indeed the solution (3.1) to the modified
 $\unicode[STIX]{x1D6FD}$
-plane model admits both following and adverse currents of any physically plausible (in the sense that relation (3.4) holds) magnitude.
While the consideration of underlying currents in wave motion, and in particular wave–current interactions, is a compelling subject in itself from a purely mathematical viewpoint, these physical processes are evidently highly important in a variety of contexts (Mollo-Christensen Reference Mollo-Christensen1978; Constantin Reference Constantin2011). The presence of strong currents in the equatorial Pacific is well documented, and they feature significantly in the geophysical dynamics of the equatorial region (Izumo Reference Izumo2005; Federov & Brown Reference Fedorov, Brown and Steele2009; Cushman-Roisin & Beckers Reference Cushman-Roisin and Beckers2011; Constantin & Johnson Reference Constantin and Johnson2015, Reference Constantin and Johnson2016). We note that while the underlying current in the exact solution (3.1) assumes an apparently simple form in the Lagrangian setting, it leads to significant complexifications, both mathematically and physically, in the resulting fluid motion (Genoud & Henry Reference Genoud and Henry2014; Henry & Sastre-Gómez Reference Henry and Sastre-Gómez2016). This is perhaps not surprising since the nonlinear passage from Lagrangian to Eulerian coordinates is a delicate issue. Furthermore, we note that while the existence of an exact finite-amplitude solution to a given water wave problem is remarkable, due to the inherent rarity of such solutions, it is also noteworthy that such solutions (particularly if they are explicit) offer an opportunity to generate more general and useful solutions, representing more physically complex flows, by way of employing perturbative or asymptotic considerations, for example.
2 Preliminaries
We begin this section by first presenting the governing equations of geophysical fluid motion in cylindrical coordinates, and from this framework we derive the appropriate
 $\unicode[STIX]{x1D6FD}$
-plane approximation. Both systems are highly nonlinear, and the
 $\unicode[STIX]{x1D6FD}$
-plane approximation utilizes the idea that if the spatial scale of motion on the spherical domain is moderate enough then the horizontal region occupied by the fluid domain can be approximated as a tangent plane. This framework was recently exploited in Constantin & Johnson (Reference Constantin and Johnson2016), where the authors found a new exact solution of the full governing equations which does not vary azimuthally (in spherical coordinates), and this new exact solution was shown to have (more tractable, yet physically illustrative) analogue solutions when transformed to the settings of both cylindrical coordinates and the
 $\unicode[STIX]{x1D6FD}$
-plane approximation. From our viewpoint, the wave-like terms in the exact solution we present below may be regarded as being in a sense ‘azimuthally periodic’. The cylindrical coordinates
 $(x,\unicode[STIX]{x1D703},z)$
are chosen such that the origin is located at the centre of the Earth, the generator of the cylinder is the
 $x$
-axis which represents the ‘straightened-out’ equator (with the positive
 $x$
-direction going from west to east),
 $\unicode[STIX]{x1D703}$
is the angle of latitude (and not the typical polar angle) and we set
 $z=r-R$
to be the variation in the locally vertical direction of the radial variable from the Earth’s surface. The geophysical parameters we employ are as follows:
 $g=9.8~\text{m}~\text{s}^{-2}$
is the standard gravitational acceleration,
 $R=6378~\text{km}$
is the Earth’s radius (we make the assumption that the Earth is a perfect sphere),
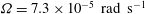 $\unicode[STIX]{x1D6FA}=7.3\times 10^{-5}~\text{rad}~\text{s}^{-1}$
is the (constant) rotational speed of the Earth and
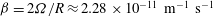 $\unicode[STIX]{x1D6FD}=2\unicode[STIX]{x1D6FA}/R\approx 2.28\times 10^{-11}~\text{m}^{-1}~\text{s}^{-1}$
; cf. Cushman-Roisin & Beckers (Reference Cushman-Roisin and Beckers2011). The Euler equation for fluid motion in these cylindrical coordinates (cf. Constantin & Johnson (Reference Constantin and Johnson2016) for details) assumes the form
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}\displaystyle u_{t}+uu_{x}+\frac{v}{R+z}u_{\unicode[STIX]{x1D703}}+wu_{z}+2\unicode[STIX]{x1D6FA}(w\cos \unicode[STIX]{x1D703}-v\sin \unicode[STIX]{x1D703})=-\frac{1}{\unicode[STIX]{x1D70C}}P_{x},\\ \displaystyle v_{t}+uv_{x}+\frac{vv_{\unicode[STIX]{x1D703}}}{R+z}+\frac{wv}{R+z}+2\unicode[STIX]{x1D6FA}u\sin \unicode[STIX]{x1D703}+(R+z)\unicode[STIX]{x1D6FA}^{2}\sin \unicode[STIX]{x1D703}\cos \unicode[STIX]{x1D703}=-\frac{1}{\unicode[STIX]{x1D70C}}\frac{P_{\unicode[STIX]{x1D703}}}{R+z},\\ \displaystyle w_{t}+uw_{x}+\frac{vw_{\unicode[STIX]{x1D703}}}{R+z}+ww_{z}-\frac{v^{2}}{R+z}-2\unicode[STIX]{x1D6FA}u\cos \unicode[STIX]{x1D703}-(R+z)\unicode[STIX]{x1D6FA}^{2}\cos ^{2}\unicode[STIX]{x1D703}=-\frac{1}{\unicode[STIX]{x1D70C}}P_{z}-g,\end{array}\right\}\end{eqnarray}$$
together with the equation for incompressibility
 $$\begin{eqnarray}u_{x}+\frac{1}{R+z}v_{\unicode[STIX]{x1D703}}+\frac{1}{R+z}\frac{\unicode[STIX]{x2202}\phantom{z}}{\unicode[STIX]{x2202}z}[(R+z)w]=0.\end{eqnarray}$$
Here,
 $(u,v,w)$
is the fluid velocity field in the
 $(\boldsymbol{e}_{x},\boldsymbol{e}_{\unicode[STIX]{x1D703}},\boldsymbol{e}_{z})$
directions,
 $\unicode[STIX]{x1D70C}$
is the water density (which we take to be constant, although see § 4.2 for a discussion on stratified or variable density fluid) and
 $P$
is the pressure distribution. Terms in (2.1a
) involving
 $\unicode[STIX]{x1D6FA}$
to the first order of magnitude represent Coriolis forces, whereas terms of the order
 $\unicode[STIX]{x1D6FA}^{2}$
denote centripetal forces. Typically, in an oceanographic context, centripetal terms are neglected due to their comparably small size. However, we retain them here in our consideration of wave-like solutions, and remarkably it will become apparent that centripetal forces play an important role in ensuring that the exact solution we present below can admit all physically plausible ranges of underlying currents. Indeed, we can see by comparison with Henry (Reference Henry2013) that this robust admissibility property of all physically plausible ranges of underlying currents in our solution hinges completely on the presence of the centripetal forces. We note that this phenomenon whereby Coriolis terms, although negligible in general oceanographic considerations, can perform an important role in specific wave (and wave–current) dynamics, while curious, may be observed in other geophysical fluid dynamical contexts, an example being Rossby waves (see Cushman-Roisin & Beckers Reference Cushman-Roisin and Beckers2011).
The
 $\unicode[STIX]{x1D6FD}$
-plane approximation results under the assumption that we are close to the equator, namely we are restricted to latitudes in the region
 $s\in [-s_{0},s_{0}]$
, where
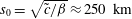 $s_{0}=\sqrt{\tilde{c}/\unicode[STIX]{x1D6FD}}\approx 250~\text{km}$
is a typical value for the equatorial radius of deformation (and
 $\tilde{c}$
is a characteristic geophysical wavespeed; cf. Cushman-Roisin & Beckers (Reference Cushman-Roisin and Beckers2011)). Mathematically, this corresponds to an assumption that
 $\unicode[STIX]{x1D703}\rightarrow 0$
, and furthermore the radius
 $R$
is very large relative to the vertical variations
 $z$
, whence
 $z/R\rightarrow 0$
. Defining
 $y=R\unicode[STIX]{x1D703}$
and retaining only terms of linear order
 $(O(\unicode[STIX]{x1D703}))$
in the expansion of the trigonometric functions in (2.1) we get the
 $\unicode[STIX]{x1D6FD}$
-plane governing equations,
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}\displaystyle u_{t}+uu_{x}+vu_{y}+wu_{z}+2\unicode[STIX]{x1D6FA}w-\unicode[STIX]{x1D6FD}yv=-\frac{1}{\unicode[STIX]{x1D70C}}P_{x},\\ \displaystyle v_{t}+uv_{x}+vv_{y}+wv_{z}+\unicode[STIX]{x1D6FD}yu+\unicode[STIX]{x1D6FA}^{2}y=-\frac{1}{\unicode[STIX]{x1D70C}}P_{y},\\ \displaystyle w_{t}+uw_{x}+vw_{y}+ww_{z}-2\unicode[STIX]{x1D6FA}u-\unicode[STIX]{x1D6FA}^{2}R=-\frac{1}{\unicode[STIX]{x1D70C}}P_{z}-g,\end{array}\right\}\end{eqnarray}$$
together with the equation of incompressibility,
 $$\begin{eqnarray}u_{x}+v_{y}+w_{z}=0.\end{eqnarray}$$
Denoting the free surface by
 $\unicode[STIX]{x1D702}(x,y,t)$
and letting
 $P_{atm}$
be the (constant) atmospheric pressure, the relevant boundary conditions at the free surface are the kinematic boundary condition
 $$\begin{eqnarray}w=\unicode[STIX]{x1D702}_{t}+u\unicode[STIX]{x1D702}_{x}+v\unicode[STIX]{x1D702}_{y}\quad \text{on }z=\unicode[STIX]{x1D702}(x,y,t),\end{eqnarray}$$
which implies that fluid particles on the free surface remain on the surface for all time, and the dynamic boundary condition
 $$\begin{eqnarray}P=P_{atm}\quad \text{on }z=\unicode[STIX]{x1D702}(x,y,t),\end{eqnarray}$$
which decouples the water flow from the motion of the air above. Finally, we assume the water to be infinitely deep, with the flow converging rapidly with depth to a uniform zonal current; that is,
 $$\begin{eqnarray}(u,v,w)\rightarrow (-c_{0},0,0)\quad \text{as }z\rightarrow -\infty .\end{eqnarray}$$
The set of (2.2) comprises the governing equations for the modified
 $\unicode[STIX]{x1D6FD}$
-plane approximation of geophysical ocean waves with a free surface.
We remark that the system (2.2a
) requires a very specific pressure distribution in the absence of motion (
 $u=v=w=0$
): if the free surface is a surface of constant atmospheric pressure (
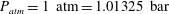 $P_{atm}=1~\text{atm}=1.01325~\text{bar}$
), then
 $$\begin{eqnarray}P(x,y,z,t)=P_{atm}-{\textstyle \frac{1}{2}}\unicode[STIX]{x1D70C}\unicode[STIX]{x1D6FA}^{2}y^{2}+\unicode[STIX]{x1D70C}(\unicode[STIX]{x1D6FA}^{2}R-g)z\end{eqnarray}$$
throughout the fluid, so that the free surface is given by
 $$\begin{eqnarray}z=\frac{P_{atm}}{\unicode[STIX]{x1D70C}(g-\unicode[STIX]{x1D6FA}^{2}R)}-\frac{\unicode[STIX]{x1D6FA}^{2}}{2(g-\unicode[STIX]{x1D6FA}^{2}R)}y^{2}\approx \frac{P_{atm}}{\unicode[STIX]{x1D70C}g}-\frac{\unicode[STIX]{x1D6FA}^{2}}{2g}y^{2}\end{eqnarray}$$
since
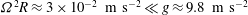 $\unicode[STIX]{x1D6FA}^{2}R\approx 3\times 10^{-2}~\text{m}~\text{s}^{-2}\ll g\approx 9.8~\text{m}~\text{s}^{-2}$
. The above distortion from a constant value of
 $z$
corresponds to a free surface following the curvature of the Earth away from the equator, as the curved surface of the Earth drops below the tangent plane at the equator – this is consistent with, and indeed a consequence of, the
 $\unicode[STIX]{x1D6FD}$
-plane approximation.
3 Main result
The aim of this section is to explicitly show that, for all physically admissible values of the underlying current
 $c_{0}$
(taken to be uniform), the fluid motion prescribed by
 $$\begin{eqnarray}\displaystyle & \displaystyle x=q-c_{0}t-\frac{1}{k}\text{e}^{k[r-f(s)]}\sin [k(q-ct)], & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle y=s, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle z=r+\frac{1}{k}\text{e}^{k[r-f(s)]}\cos [k(q-ct)], & \displaystyle\end{eqnarray}$$
 $\unicode[STIX]{x1D6FD}$
-plane governing equations (2.2). Here, the Eulerian coordinates of fluid particles
 $(x,y,z)$
are expressed as functions of the Lagrangian labelling variables
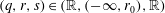 $(q,r,s)\in (\mathbb{R},(-\infty ,r_{0}),\mathbb{R})$
and time
 $t$
, where
 $r_{0}<0$
and
 $k=2\unicode[STIX]{x03C0}/L$
is the wavenumber with
 $L$
the wavelength. Regarding the latitudinal
 $s$
parameter, although we demonstrate below that the formula (3.1) defines a mathematical solution of the system (2.2) for all values of
 $s\in \mathbb{R}$
, purely geophysical considerations imply that we work in a restricted region
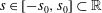 $s\in [-s_{0},s_{0}]\subset \mathbb{R}$
for which the
 $\unicode[STIX]{x1D6FD}$
-plane approximation is applicable. The solution (3.1) prescribes a three-dimensional eastward-propagating steady geophysical wave in the presence of a constant underlying current of magnitude
 $|c_{0}|$
. For
 $c_{0}>0$
the underlying current is adverse, while for
 $c_{0}<0$
the current is following. The wave-like term is periodic in the zonal (azimuthal) direction and it has a constant wave phasespeed
 $c>0$
which will be prescribed by the dispersion relation (4.18) below. The role of the function
 $f(s)$
, defined by
 $$\begin{eqnarray}f(s)=\frac{c\unicode[STIX]{x1D6FD}}{2\mathfrak{g}}s^{2},\end{eqnarray}$$
is to enforce a strong exponential decay in fluid particle oscillations meridionally, thereby ensuring that the wave is equatorially trapped. We define
 $$\begin{eqnarray}\mathfrak{g}=g+2\unicode[STIX]{x1D6FA}c_{0}-\unicode[STIX]{x1D6FA}^{2}R>0\end{eqnarray}$$
to be a modification of standard gravitational acceleration with additional terms due to Coriolis effects and the underlying constant current. We infer that the inequality holds above in (3.3) since otherwise we would have
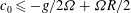 $c_{0}\leqslant -g/2\unicode[STIX]{x1D6FA}+\unicode[STIX]{x1D6FA}R/2$
, a scenario we can exclude on physical grounds bearing in mind that
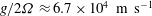 $g/2\unicode[STIX]{x1D6FA}\approx 6.7\times 10^{4}~\text{m}~\text{s}^{-1}$
,
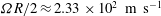 $\unicode[STIX]{x1D6FA}R/2\approx 2.33\times 10^{2}~\text{m}~\text{s}^{-1}$
. We now state the main result of this paper as follows.
Proposition 1. The fluid motion prescribed by (3.1) represents an exact solution of the governing equations (2.2) if the underlying current
 $c_{0}$
satisfies
 $$\begin{eqnarray}c_{0}<\frac{\unicode[STIX]{x1D6FA}R}{2}\approx 2.33\times 10^{2}~\text{m}~\text{s}^{-1}.\end{eqnarray}$$
Henceforth, such values of
 $c_{0}$
will be referred to as ‘physically plausible’. The free surface
 $z=\unicode[STIX]{x1D702}(x,y,t)$
is implicitly prescribed at the equator
 $(y=s=0)$
by setting
 $r=r_{0}$
in (3.1), and for any other fixed latitude
 $s\in [-s_{0},s_{0}]$
, whenever (3.4) holds, there exists a unique value
 $r(s)<r_{0}$
which implicitly prescribes the free surface
 $z=\unicode[STIX]{x1D702}(x,s,t)$
by way of setting
 $r=r(s)$
in (3.1).
We will see in § 4 that one of the primary obstacles in incorporating an underlying current term (and the motivation for condition (3.4)) lies in proving the existence of a unique solution
 $r(s)<r_{0}$
to (4.13) which prescribes the free surface at each fixed latitude, parameterized by the Langrangian labelling variable
 $q$
. We note that this method of prescription of the free surface
 $z=\unicode[STIX]{x1D702}(x,y,t)$
ensures that the kinematic boundary condition (2.2c
) holds by design. In the absence of a current (
 $c_{0}=0$
), at each fixed latitude the free surface is an inverted trochoid (Constantin Reference Constantin2011, Reference Constantin2012; Henry Reference Henry2013) and furthermore particle trajectories take the form of closed circles. It should be noted that closed particle trajectories are encountered beneath periodic travelling surface gravity water waves very rarely in irrotational flow and, when so, only isolated and at specific depths (see the theoretical considerations in Constantin (Reference Constantin2006), Henry (Reference Henry2008) and Constantin & Strauss (Reference Constantin and Strauss2010) confirmed numerically in Nachbin & Ribeiro-Junior (Reference Nachbin and Ribeiro-Junior2014) and experimentally in Umeyama (Reference Umeyama2012)). The fact that this feature is indicative of flows with vorticity will be expanded upon in § 4.
The field data examined in Moum, Nash & Smyth (Reference Moum, Nash and Smyth2011) highlight the importance of waves with relatively short wavelengths (in the range 150–250 m) for the dynamics of the upper-equatorial oceans. It should be noted that the vanishing of the meridional component of the Coriolis force at the equator has the effect that the equator works as a (fictitious) natural boundary, facilitating azimuthal flow propagation. Moreover, equatorial field data (see Johnson, McPhaden & Firing (Reference Johnson, McPhaden and Firing2001)) confirm the fact that meridional speeds near the equator are much smaller than the zonal speeds, and neglecting them, as the prescribed fluid motion (3.1) does, therefore has an insignificant dynamical effect. All of these observations show that wave patterns of the type predicted by our considerations are relevant for the ocean dynamics in the equatorial Pacific. We point out that while our theoretical considerations were restricted to roughly
 $2^{\circ }$
of latitude from the equator (since further away the underlying current structure starts to present significant changes), wave patterns of the type described in this paper quite accurately match observations recorded within 50–100 km of the equator.
4 Fluid kinematics
To examine aspects of the fluid motion prescribed by the exact solution (3.1) we take advantage of working in the Lagrangian framework, a characteristic of which is that the fluid kinematics can often be ascertained explicitly and with relative ease – a nice exposition of general characteristics of the Lagrangian approach to fluid dynamics can be found in Bennett (Reference Bennett2006). For ease of notation we denote
 $\unicode[STIX]{x1D709}=k(r-f(s))$
and
 $\unicode[STIX]{x1D703}=k(q-ct)$
, and the Jacobian matrix of the transformation (3.1) is computed as
 $$\begin{eqnarray}\frac{\unicode[STIX]{x2202}(x,y,z)}{\unicode[STIX]{x2202}(q,s,r)}=\left(\begin{array}{@{}ccc@{}}\displaystyle \frac{\unicode[STIX]{x2202}x}{\unicode[STIX]{x2202}q} & \displaystyle \frac{\unicode[STIX]{x2202}y}{\unicode[STIX]{x2202}q} & \displaystyle \frac{\unicode[STIX]{x2202}z}{\unicode[STIX]{x2202}q}\\ \displaystyle \frac{\unicode[STIX]{x2202}x}{\unicode[STIX]{x2202}s} & \displaystyle \frac{\unicode[STIX]{x2202}y}{\unicode[STIX]{x2202}s} & \displaystyle \frac{\unicode[STIX]{x2202}z}{\unicode[STIX]{x2202}s}\\ \displaystyle \frac{\unicode[STIX]{x2202}x}{\unicode[STIX]{x2202}r} & \displaystyle \frac{\unicode[STIX]{x2202}y}{\unicode[STIX]{x2202}r} & \displaystyle \frac{\unicode[STIX]{x2202}z}{\unicode[STIX]{x2202}r}\end{array}\right)=\left(\begin{array}{@{}ccc@{}}\displaystyle 1-\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703} & 0 & -\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703}\\ \displaystyle f_{s}\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703} & 1 & -f_{s}\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}\\ \displaystyle -\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703} & 0 & 1+\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}\end{array}\right).\end{eqnarray}$$
The determinant of the Jacobian is
 $1-\text{e}^{2\unicode[STIX]{x1D709}}$
, which is non-zero (and hence the transformation (3.1) is well defined) if
 $$\begin{eqnarray}r-f(s)\leqslant r_{0}<0.\end{eqnarray}$$
A consequence of (4.2) is that we must have
 $c>0$
in order for our flow to exhibit both meridional and vertical oscillatory decay, a fact that has further implications when we derive the dispersion relation in (4.18) below. Furthermore, as
 $1-\text{e}^{2\unicode[STIX]{x1D709}}$
is time-independent, the flow defined by (3.1) must be volume preserving, ensuring that (2.2b
) holds in the Eulerian setting (Bennett Reference Bennett2006; Constantin Reference Constantin2011). Since the solution (3.1) is explicit in the Lagrangian formulation, by direct calculation we may immediately discern some qualitative properties of the fluid kinematics:
 $$\begin{eqnarray}u=\frac{\text{D}x}{\text{D}t}=c\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}-c_{0},\quad \frac{\text{D}u}{\text{D}t}=kc^{2}\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703},\end{eqnarray}$$
 $$\begin{eqnarray}v=\frac{\text{D}y}{\text{D}t}=0,\quad \frac{\text{D}v}{\text{D}t}=0,\end{eqnarray}$$
 $$\begin{eqnarray}w=\frac{\text{D}z}{\text{D}t}=c\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703},\quad \frac{\text{D}w}{\text{D}t}=-kc^{2}\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703},\end{eqnarray}$$
where
 $\text{D}/\text{D}t$
is the material derivative. The fact that
 $v\equiv 0$
throughout the fluid is in keeping with (and indeed necessary for) the equatorially trapped nature of the flow. The vorticity of the flow prescribed by (3.1) is determined by way of computing
 $$\begin{eqnarray}\displaystyle \left(\begin{array}{@{}ccc@{}}\displaystyle \frac{\unicode[STIX]{x2202}u}{\unicode[STIX]{x2202}x} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}x} & \displaystyle \frac{\unicode[STIX]{x2202}w}{\unicode[STIX]{x2202}x}\\ \displaystyle \frac{\unicode[STIX]{x2202}u}{\unicode[STIX]{x2202}y} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}y} & \displaystyle \frac{\unicode[STIX]{x2202}w}{\unicode[STIX]{x2202}y}\\ \displaystyle \frac{\unicode[STIX]{x2202}u}{\unicode[STIX]{x2202}z} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}z} & \displaystyle \frac{\unicode[STIX]{x2202}w}{\unicode[STIX]{x2202}z}\end{array}\right) & = & \displaystyle \left(\begin{array}{@{}ccc@{}}\displaystyle \frac{\unicode[STIX]{x2202}q}{\unicode[STIX]{x2202}x} & \displaystyle \frac{\unicode[STIX]{x2202}s}{\unicode[STIX]{x2202}x} & \displaystyle \frac{\unicode[STIX]{x2202}r}{\unicode[STIX]{x2202}x}\\ \displaystyle \frac{\unicode[STIX]{x2202}q}{\unicode[STIX]{x2202}y} & \displaystyle \frac{\unicode[STIX]{x2202}s}{\unicode[STIX]{x2202}y} & \displaystyle \frac{\unicode[STIX]{x2202}r}{\unicode[STIX]{x2202}y}\\ \displaystyle \frac{\unicode[STIX]{x2202}q}{\unicode[STIX]{x2202}z} & \displaystyle \frac{\unicode[STIX]{x2202}s}{\unicode[STIX]{x2202}z} & \displaystyle \frac{\unicode[STIX]{x2202}r}{\unicode[STIX]{x2202}z}\end{array}\right)\left(\begin{array}{@{}ccc@{}}\displaystyle \frac{\unicode[STIX]{x2202}u}{\unicode[STIX]{x2202}q} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}q} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}q}\\ \displaystyle \frac{\unicode[STIX]{x2202}u}{\unicode[STIX]{x2202}s} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}s} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}s}\\ \displaystyle \frac{\unicode[STIX]{x2202}u}{\unicode[STIX]{x2202}r} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}r} & \displaystyle \frac{\unicode[STIX]{x2202}v}{\unicode[STIX]{x2202}r}\end{array}\right)\nonumber\\ \displaystyle & = & \displaystyle \frac{ck\text{e}^{\unicode[STIX]{x1D709}}}{1-\text{e}^{2\unicode[STIX]{x1D709}}}\left(\begin{array}{@{}ccc@{}}-\sin \unicode[STIX]{x1D703} & 0 & \cos \unicode[STIX]{x1D703}+\text{e}^{\unicode[STIX]{x1D709}}\\ f_{s}(\text{e}^{\unicode[STIX]{x1D709}}-\cos \unicode[STIX]{x1D703}) & 0 & -f_{s}\sin \unicode[STIX]{x1D703}\\ -\text{e}^{\unicode[STIX]{x1D709}}+\cos \unicode[STIX]{x1D703} & 0 & \sin \unicode[STIX]{x1D703}\end{array}\right),\end{eqnarray}$$
and accordingly the vorticity takes the form
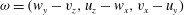 $\unicode[STIX]{x1D714}=(w_{y}-v_{z},u_{z}-w_{x},v_{x}-u_{y})$
 $$\begin{eqnarray}\displaystyle =\left(-s\frac{kc^{2}\unicode[STIX]{x1D6FD}}{g}\frac{\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703}}{1-\text{e}^{2\unicode[STIX]{x1D709}}},-\frac{2kc\text{e}^{2\unicode[STIX]{x1D709}}}{1-\text{e}^{2\unicode[STIX]{x1D709}}},s\frac{kc^{2}\unicode[STIX]{x1D6FD}}{g}\frac{\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}-\text{e}^{2\unicode[STIX]{x1D709}}}{1-\text{e}^{2\unicode[STIX]{x1D709}}}\right). & & \displaystyle\end{eqnarray}$$
We note that since the current is constant it does not impact on the vorticity (4.5) of the flow directly, yet it has an indirect influence through the formulation of the wavespeed
 $c$
given by the dispersion relation (4.18). Furthermore, the vorticity (4.5) is (weakly) three-dimensional away from the equator, and it becomes one-dimensional either at the equator (
 $s=0$
) or by neglecting Coriolis effects (letting
 $\unicode[STIX]{x1D6FD}\rightarrow 0$
). Using (4.3) we can express (2.2a
) as
 $$\begin{eqnarray}\displaystyle & P_{x}=-\unicode[STIX]{x1D70C}(kc^{2}\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703}+2\unicode[STIX]{x1D6FA}c\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & P_{y}=-\unicode[STIX]{x1D70C}(\unicode[STIX]{x1D6FD}s[c\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}-c_{0}]+\unicode[STIX]{x1D6FA}^{2}s), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & P_{z}=-\unicode[STIX]{x1D70C}(-kc^{2}\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}-2\unicode[STIX]{x1D6FA}c\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}+\mathfrak{g}), & \displaystyle\end{eqnarray}$$
 $\mathfrak{g}$
defined by (3.3) above. By multiplying both sides of (4.6) by the Jacobian matrix (4.1) we obtain an expression for the pressure gradient in terms of the Lagrangian variables:
 $$\begin{eqnarray}\displaystyle \left(\begin{array}{@{}c@{}}P_{q}\\ P_{s}\\ P_{r}\end{array}\right)=-\unicode[STIX]{x1D70C}\left(\begin{array}{@{}c@{}}(kc^{2}+2\unicode[STIX]{x1D6FA}c-\mathfrak{g})\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703}\\ f_{s}\text{e}^{2\unicode[STIX]{x1D709}}(kc^{2}+2\unicode[STIX]{x1D6FA}c)+(\unicode[STIX]{x1D6FD}sc-f_{s}\mathfrak{g})\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}-\unicode[STIX]{x1D6FD}sc_{0}+\unicode[STIX]{x1D6FA}^{2}s\\ -(kc^{2}+2\unicode[STIX]{x1D6FA}c)\text{e}^{2\unicode[STIX]{x1D709}}-(kc^{2}+2\unicode[STIX]{x1D6FA}c-\mathfrak{g})\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}+\mathfrak{g}\end{array}\right). & & \displaystyle\end{eqnarray}$$
The next stage in proving that (3.1) represents an exact solution of (2.2) is to construct a suitable pressure function
 $P$
such that (4.7), and also (2.2d
), holds. Choosing
 $$\begin{eqnarray}\tilde{P}=\unicode[STIX]{x1D70C}\frac{kc^{2}+2\unicode[STIX]{x1D6FA}c}{2k}\text{e}^{2\unicode[STIX]{x1D709}}-\unicode[STIX]{x1D70C}\mathfrak{g}r+\frac{\unicode[STIX]{x1D70C}\mathfrak{g}}{c}f(s)\left(c_{0}-\frac{R\unicode[STIX]{x1D6FA}}{2}\right)+\unicode[STIX]{x1D70C}\frac{kc^{2}+2\unicode[STIX]{x1D6FA}c-\mathfrak{g}}{k}\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}+\tilde{P}_{0}\end{eqnarray}$$
gives
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}\tilde{P}_{q}=-\unicode[STIX]{x1D70C}(kc^{2}+2\unicode[STIX]{x1D6FA}c-\mathfrak{g})\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703},\\ \tilde{P}_{s}=-\unicode[STIX]{x1D70C}(kc^{2}+2\unicode[STIX]{x1D6FA}c)f_{s}\text{e}^{2\unicode[STIX]{x1D709}}-\unicode[STIX]{x1D70C}(kc^{2}+2\unicode[STIX]{x1D6FA}c-\mathfrak{g})f_{s}\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}+\unicode[STIX]{x1D70C}\unicode[STIX]{x1D6FD}sc_{0}-\unicode[STIX]{x1D70C}\unicode[STIX]{x1D6FA}^{2}s,\\ \tilde{P}_{r}=\unicode[STIX]{x1D70C}(kc^{2}+2\unicode[STIX]{x1D6FA}c)\text{e}^{2\unicode[STIX]{x1D709}}-\unicode[STIX]{x1D70C}\mathfrak{g}+\unicode[STIX]{x1D70C}(kc^{2}+2\unicode[STIX]{x1D6FA}c-\mathfrak{g})\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703}.\end{array}\right\}\end{eqnarray}$$
To satisfy (2.2d
), which enforces a time independence in the pressure function at the surface, it is necessary to eliminate terms containing
 $\unicode[STIX]{x1D703}$
in (4.8) by setting
 $$\begin{eqnarray}kc^{2}+2\unicode[STIX]{x1D6FA}c-\mathfrak{g}=kc^{2}+2\unicode[STIX]{x1D6FA}c-2\unicode[STIX]{x1D6FA}c_{0}-g+\unicode[STIX]{x1D6FA}^{2}R=0.\end{eqnarray}$$
The first implication of relation (4.10) is that the function
 $f(s)$
, defined by (3.2), has an alternative form which will be useful in calculations, namely
 $$\begin{eqnarray}f(s)=\frac{c\unicode[STIX]{x1D6FD}}{2\mathfrak{g}}s^{2}=\frac{\unicode[STIX]{x1D6FD}}{2(kc+2\unicode[STIX]{x1D6FA})}s^{2}.\end{eqnarray}$$
It now follows directly from (4.11) that the pressure gradient expression (4.9) matches (4.7). Using (4.10) in relation (4.8), we infer that the choice of pressure function
 $$\begin{eqnarray}P(r,s)=\unicode[STIX]{x1D70C}\mathfrak{g}\left(\frac{\text{e}^{2\unicode[STIX]{x1D709}}}{2k}-r+\frac{f(s)}{c}\left(c_{0}-\frac{\unicode[STIX]{x1D6FA}R}{2}\right)\right)+P_{atm}-\unicode[STIX]{x1D70C}\mathfrak{g}\left(\frac{\text{e}^{2kr_{0}}}{2k}-r_{0}\right),\end{eqnarray}$$
together with the flow determined by (3.1), satisfies the governing equations (2.2a
). The constant terms on the right-hand side of (4.12) have been chosen bearing in mind the last step in our process, which is to ensure that conditions (2.2c
) and (2.2d
) hold on the free surface. This is achieved if we show that, for each fixed latitude
 $s$
, there exists a unique solution
 $r(s)\leqslant r_{0}<0$
such that
 $P(r(s),s)=P_{atm}$
in (4.12), which is equivalent to
 $$\begin{eqnarray}\mathscr{P}(r(s),s)=\frac{\text{e}^{2kr_{0}}}{2k}+r_{0},\end{eqnarray}$$
where
 $$\begin{eqnarray}\mathscr{P}(r,s):=\frac{\text{e}^{2k[r-(c\unicode[STIX]{x1D6FD}/2\mathfrak{g})s^{2}]}}{2k}-r+\frac{\unicode[STIX]{x1D6FD}}{2\mathfrak{g}}\left(c_{0}-\frac{\unicode[STIX]{x1D6FA}R}{2}\right)s^{2}.\end{eqnarray}$$
At the equator, for
 $s=0$
, the choice
 $r(0)=r_{0}$
works in (4.13). For
 $|s|>0$
, we infer that the last term on the right-hand side above is negative for physically plausible values
 $c_{0}$
such that (3.4) holds, bearing in mind (3.3), and so
 $\mathscr{P}(r,s)$
decreases as
 $|s|$
increases. It then follows that, for each fixed
 $s\neq 0$
, there exists a unique
 $r(s)$
such that the equilibrium (4.13) holds, since
 $$\begin{eqnarray}\mathscr{P}_{r}(r,s)=\text{e}^{2k[r-(c\unicode[STIX]{x1D6FD}/2\mathfrak{g})s^{2}]}-1<0\end{eqnarray}$$
implies that
 $\mathscr{P}(r,s)$
is a monotonically decreasing function of
 $r$
, and furthermore
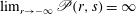 $\lim _{r\rightarrow -\infty }\mathscr{P}(r,s)=\infty$
. Finally, differentiating (4.13) with respect to
 $s$
we have
 $$\begin{eqnarray}\left(r^{\prime }(s)-\frac{c\unicode[STIX]{x1D6FD}}{\mathfrak{g}}s\right)\text{e}^{2k[r-(c\unicode[STIX]{x1D6FD}/2\mathfrak{g})s^{2}]}-r^{\prime }(s)+\frac{\unicode[STIX]{x1D6FD}}{\mathfrak{g}}\left(c_{0}-\frac{\unicode[STIX]{x1D6FA}R}{2}\right)s=0,\end{eqnarray}$$
which by way of (3.4) gives us
 $$\begin{eqnarray}r^{\prime }(s)=\frac{\unicode[STIX]{x1D6FD}s}{\mathfrak{g}}\cdot \frac{c_{0}-\displaystyle \frac{\unicode[STIX]{x1D6FA}R}{2}-c\text{e}^{2k[r-(c\unicode[STIX]{x1D6FD}/2\mathfrak{g})s^{2}]}}{1-\text{e}^{2k[r-(c\unicode[STIX]{x1D6FD}/2\mathfrak{g})s^{2}]}}<0,\end{eqnarray}$$
and so the even function
 $s\mapsto r(s)$
is decreasing whenever condition (3.4) holds. This completes the proof of Proposition 1.
4.1 Dispersion relations
We remark that relation (4.10) has additional implications in determining the dispersion relation for the wave motion prescribed by (3.1) by way of regarding (4.10) as a quadratic in
 $c$
. We first note that if
 $c_{0}=c$
then (4.10) implies that
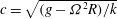 $c=\sqrt{(g-\unicode[STIX]{x1D6FA}^{2}R)/k}$
: for sufficiently large wavenumbers
 $k$
(corresponding to sufficiently small wavelengths
 $L$
), the magnitude of the underlying current
 $c_{0}$
given by this relation may, in principle, be physically attainable, and furthermore it does not contravene the bound given by (3.4). This dispersion relation is a perturbation of the standard Gerstner wave (and deep-water gravity water wave) dispersion relation
 $c=\sqrt{g/k}$
by additional Coriolis terms which are attributable to the centripetal force. Indeed, the potential balance between the wave phasespeed and the adverse current prescribed by
 $c=c_{0}$
is a curious phenomenon which is unique to the modified
 $\unicode[STIX]{x1D6FD}$
-plane formulation considered in this paper, since it is expressly prohibited by the absence of centripetal terms; cf. Henry (Reference Henry2013) for details. In the more general scenario with
 $c_{0}\neq c$
, solving (4.10) for the positive root (to ensure
 $c>0$
) gives the dispersion relation
 $$\begin{eqnarray}c=\frac{\sqrt{\unicode[STIX]{x1D6FA}^{2}+k(g+2\unicode[STIX]{x1D6FA}c_{0}-\unicode[STIX]{x1D6FA}^{2}R)}-\unicode[STIX]{x1D6FA}}{k},\end{eqnarray}$$
which is well defined due to (3.3), and which features contributions from the Coriolis force, the centripetal force and the underlying current. Ignoring the effects of the Earth’s rotation (letting
 $\unicode[STIX]{x1D6FA}\rightarrow 0$
), we recover the standard expression for the deep-water gravity water wave (and Gerstner wave) dispersion relation, namely
 $c=\sqrt{g/k}$
. Surface waves with wavelengths of 300 m, propagating at speeds of approximately
 $22~\text{m}~\text{s}^{-1}$
, are common in the Pacific (see the discussion in Constantin (Reference Constantin2012)); the corresponding value of the speed predicted by the dispersion relation
 $c=\sqrt{g/k}$
is therefore quite accurate. For further relevant field data we refer to the discussion in Constantin & Johnson (Reference Constantin and Johnson2015).
4.2 Stratification
We note that in the absence of an underlying current (
 $c_{0}=0$
) we can allow variable density in our fluid through introducing an additional condition,
 $$\begin{eqnarray}\unicode[STIX]{x1D70C}_{t}+u\unicode[STIX]{x1D70C}_{x}+v\unicode[STIX]{x1D70C}_{y}+w\unicode[STIX]{x1D70C}_{z}=0,\end{eqnarray}$$
which must be satisfied to ensure conservation of mass. Assuming that the density has a steady functional dependence of the form
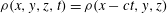 $\unicode[STIX]{x1D70C}(x,y,z,t)=\unicode[STIX]{x1D70C}(x-ct,y,z)$
, direct computation together with (4.1), (4.3) and (4.19) implies that
 $$\begin{eqnarray}\unicode[STIX]{x1D70C}_{q}=\unicode[STIX]{x1D70C}_{x}\frac{\unicode[STIX]{x2202}x}{\unicode[STIX]{x2202}q}+\unicode[STIX]{x1D70C}_{y}\frac{\unicode[STIX]{x2202}y}{\unicode[STIX]{x2202}q}+\unicode[STIX]{x1D70C}_{z}\frac{\unicode[STIX]{x2202}z}{\unicode[STIX]{x2202}q}=\unicode[STIX]{x1D70C}_{x}(1-\text{e}^{\unicode[STIX]{x1D709}}\cos \unicode[STIX]{x1D703})-\unicode[STIX]{x1D70C}_{z}\text{e}^{\unicode[STIX]{x1D709}}\sin \unicode[STIX]{x1D703}=0,\end{eqnarray}$$
and so the density
 $\unicode[STIX]{x1D70C}$
is independent of
 $q$
in terms of the Lagrangian labelling variables. It then follows that all considerations of the preceding sections transfer unhindered to the setting of stratified fluid upon prescribing the density function by
 $$\begin{eqnarray}\unicode[STIX]{x1D70C}(r,s)=F\left(\frac{\text{e}^{2\unicode[STIX]{x1D709}}}{2k}-r-\frac{\unicode[STIX]{x1D6FA}^{2}s^{2}}{2\tilde{\mathfrak{g}}}\right),\end{eqnarray}$$
where
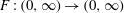 $F:(0,\infty )\rightarrow (0,\infty )$
is a non-decreasing continuously differentiable function,
 $\tilde{\mathfrak{g}}=g-\unicode[STIX]{x1D6FA}^{2}R$
and the pressure function (4.12) is suitably adapted through defining, for
 $\mathscr{F}^{\prime }=F$
with
 $\mathscr{F}(0)=0$
, the function
 $$\begin{eqnarray}P=\tilde{\mathfrak{g}}\mathscr{F}\left(\frac{\text{e}^{2\unicode[STIX]{x1D709}}}{2k}-r-\frac{\unicode[STIX]{x1D6FA}^{2}s^{2}}{2\tilde{\mathfrak{g}}}\right)+P_{atm}-\tilde{\mathfrak{g}}\mathscr{F}\left(\frac{\text{e}^{2kr_{0}}}{2k}-r_{0}\right).\end{eqnarray}$$
Acknowledgements
The author wishes to thank the three anonymous referees for their constructive comments and observations. The author acknowledges the support of the Science Foundation Ireland (SFI) research grant 13/CDA/2117.


