1. Introduction
The toe pads of frogs consist of soft thin hexagonal structures and a viscous fluid between and within the soft structures (Ernst Reference Ernst1973a ,Reference Ernst b ; Green Reference Green1979). It has been hypothesized that such a configuration enables attachment to surfaces by capillary forces (Emerson & Diehl Reference Emerson and Diehl1980; Hanna, Jon & Barnes Reference Hanna, Jon and Barnes1991; Federle Reference Federle2006), or alternatively that the channel network allows for exit of the viscous liquid and thus improves contact of the toe pad with the surface (Federle et al. Reference Federle, Barnes, Baumgartner, Drechsler and Smith2006; Persson Reference Persson2007; Tsipenyuk & Varenberg Reference Tsipenyuk and Varenberg2014). Analytical works include Federle et al. (Reference Federle, Barnes, Baumgartner, Drechsler and Smith2006), who modelled the contribution of capillary forces to shear stress on the surface, and Persson (Reference Persson2007), who studied the effect of elasticity on capillary forces.
In this work, we suggest a mechanism for creating temporary adhesion based on the interaction between viscous flow and elastic deformation. We model the toe pads of frogs as an elastic porous medium (similarly to Battiato, Bandaru & Tartakovsky Reference Battiato, Bandaru and Tartakovsky2010 and Battiato Reference Battiato2012), immersed within a viscous liquid, and pressed against a solid surface with known roughness. The dynamics of the elastic porous material are studied via the poroelastic theory (Biot Reference Biot1972; Bowen Reference Bowen1980; Ambrosi & Preziosi Reference Ambrosi and Preziosi2000). The flow between the frogs’ toe pads and the solid surface is modelled by the lubrication approximation. Forces and kinematic constraints acting on the liquid-saturated toe pad deform the material. The deformation of the porous material creates a viscous flow within the toe pads while modifying its stress field. The viscous fluid, flowing from the lubrication region into the porous material, yields a pressure field and thus effectively creates a force acting between the porous material and the surface, perpendicular to the surface. This force creates tangential friction between the porous material and the solid surface, thus preventing slip on the surface. Such a mechanism will allow for adhesion even in the absence of capillary forces and thus may explain how some frogs (such as river frogs) can maintain adhesion in the presence of rain or while being submerged (see Barnes et al. Reference Barnes, Smith, Oines and Mundl2002; Endlein et al. Reference Endlein, Ji, Samuel, Yao, Wang, Barnes, Federle, Kappl and Dai2013b ). In addition, the time-varying nature of the suggested mechanism may explain why frogs periodically reposition their toes when connected to a surface (Endlein et al. Reference Endlein, Barnes, Samuel, Crawford, Biaw and Grafe2013a ,Reference Endlein, Ji, Samuel, Yao, Wang, Barnes, Federle, Kappl and Dai b ).
The structure of this paper is as follows. In the next section, we illustrate the concept experimentally by a simplified configuration consisting of two surfaces connected by a liquid bridge and elastic springs. In § 3.1 we define the poroelastic problem. In § 3.2 we analyse the flow field and deformation field within the poroelastic medium. In § 3.3 we analyse the flow in the lubrication region between the toe pad and the solid surface, and in § 3.4 we obtain a governing equation for the dynamics of the toe pad, present several solutions and estimate viscous–poroelastic adhesion in frogs. In § 4 we summarize the results.
2. Experimental illustration of viscous–elastic friction creation
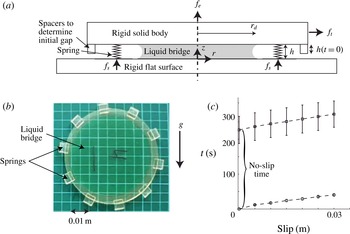
We initially focus on a simplified case in order to illustrate the effects of viscous–elastic interaction on friction. We examine the dynamics of two parallel surfaces connected by a liquid bridge and linearly elastic springs (see figure 1
a). While in this case there are no poroelastic dynamics, it includes both viscous forces and elastic forces due to the liquid bridge and the linear springs, respectively. The springs are located outside of the liquid bridge and do not affect the flow field. Friction is created by the normal force applied by the springs on the contact area with the surface. The configuration is axisymmetric. We denote the gap between the two surfaces
 $h$
, the viscosity
 ${\it\mu}$
, the surface tension
 ${\it\gamma}$
, the density
 ${\it\rho}$
, the liquid drop volume
 $v_{d}$
, the liquid radius
 $r_{d}$
, the total spring stiffness
 $k$
, the relaxed spring length
 $h_{r}$
(thus the normal force applied by the springs is
 $k(h-h_{r})$
) and the external normal force
 $f_{e}$
(see figure 1
a). Hereafter, characteristic values are denoted by asterisk superscripts. We define
 $u^{\ast }$
as the characteristic speed,
 $p^{\ast }$
as the characteristic pressure and
 $h^{\ast }$
as the characteristic gap. Following Gat, Navaz & Gharib (Reference Gat, Navaz and Gharib2011), under the assumptions of a shallow liquid bridge (
 $h^{\ast }/r_{d}\ll 1$
), negligible inertia of the liquid (
 $h^{\ast 2}{\it\rho}u^{\ast }/{\it\mu}\ll 1$
), negligible gravity (
 $g{\it\rho}h^{\ast }/p^{\ast }\ll 1$
) and negligible capillary forces (
 ${\it\gamma}v_{d}/(h^{\ast })^{2}\ll 1$
), the force balance equation is
 $$\begin{eqnarray}f_{e}-{\it\mu}\frac{3v_{d}^{2}}{2{\rm\pi}h^{5}}\frac{\text{d}h}{\text{d}t}+k(h_{r}-h)=0.\end{eqnarray}$$
The tangential friction acting at the solid interface is
 $f_{t}={\it\mu}_{s}(h_{r}-h)k$
, where
 ${\it\mu}_{s}$
is the friction coefficient. For cases in which both the springs and viscosity terms are non-negligible, an order-of-magnitude estimation yields the characteristic time scale
 $t^{\ast }={\it\mu}v_{d}^{2}/{\rm\pi}^{2}kh^{\ast 5}$
. During this time scale, the springs will apply a normal force on the surface of the order of
 ${\approx}kh^{\ast }$
, which will in turn create a tangential friction force.
(a) An illustrative front view of the model. (b) An upper view photograph of the experimental model attached to a horizontal surface with a liquid bridge between. (c) Experimental results presenting time versus slip for plates with springs (squares) and without springs (circles). Bars present standard deviation.

We conducted experiments with a circular flat plate connected to 10 extended beams acting as linear elastic springs (see figure 1
b). The solid was printed by an Objet Eden250 three-dimensional printer, and the material is Objet FullCure720. In all cases the configuration was tested immediately after printing and used only once. The liquid is a silicone oil droplet with volume
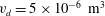 $v_{d}=5\times 10^{-6}~\text{m}^{3}$
, density
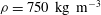 ${\it\rho}=750~\text{kg}~\text{m}^{-3}$
, surface tension
 $0.021~\text{N}~\text{m}^{-1}$
and viscosity
 ${\it\mu}=60~\text{Pa}~\text{s}$
. The plate was pressed against a rigid surface (positioned parallel to gravity; see figure 1
b) and released at
 $t=0$
. The properties of the examined configuration are
 $k\approx 4.5\times 10^{4}~\text{N}~\text{m}^{-1}$
and
 $h_{r}=1.3~\text{mm}$
. The order of magnitude of capillary forces is
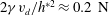 $2{\it\gamma}v_{d}/h^{\ast 2}\approx 0.2~\text{N}$
and is negligible compared with the order of magnitude of the elastic force
 $kh^{\ast }\approx 50~\text{N}$
(where
 $h^{\ast }=1~\text{mm}$
). For such a configuration, the characteristic time scale is
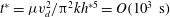 $t^{\ast }={\it\mu}v_{d}^{2}/{\rm\pi}^{2}kh^{\ast 5}=O(10^{3}~\text{s})$
. We examined six identical plates and six control plates without springs. In all cases the initial gap was determined by spacers (see figure 1
a) as
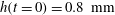 $h(t=0)=0.8~\text{mm}$
. The results are presented in figure 1(c) and clearly show enhancement of friction due to viscous–elastic interaction. While the control plates without springs immediately slipped, the configurations with springs slipped only at
 ${\approx}250~\text{s}$
.
3. Adhesion due to viscous–poroelastic interaction
We now turn to analyse a more complex case of viscous–elastic interaction involving viscous flow within an elastic porous material as a mechanism to create adhesion.
3.1. Problem definition
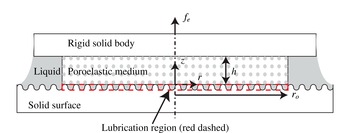
We model the interaction between an elastic porous material and a Newtonian fluid via the poroelastic mixture theory (Atkin & Craine Reference Atkin and Craine1976; Bowen Reference Bowen1980; Rajagopal & Tao Reference Rajagopal and Tao1995; Preziosi, Joseph & Beavers Reference Preziosi, Joseph and Beavers1996). We focus on axisymmetric configurations with negligible inertial and capillary effects. The relevant regions are the poroelastic region and a thin liquid-filled gap between the poroelastic region and the rough surface (marked by the dashed line (red online) in figure 2). The relevant variables are the radius of the poroelastic material
 $r_{o}$
, the poroelastic material height
 $h$
, the poroelastic material relaxed height
 $h_{r}$
(height when no stress is applied on the solid), the external force
 $f_{e}$
, the solid fraction (i.e. ratio of solid volume to total volume of liquid and solid)
 ${\it\Phi}$
, the relaxed solid fraction
 ${\it\Phi}_{r}$
, the time
 $t$
, the radial and axial coordinates
 $\boldsymbol{r}=(r,z)$
, the solid velocity
 $\boldsymbol{v}_{s}=(u_{s},v_{s},w_{s})$
, the liquid velocity
 $\boldsymbol{v}_{l}=(u_{l},v_{l},w_{l})$
, the liquid viscosity
 ${\it\mu}$
, the solid density
 ${\it\rho}_{s}$
, the liquid density
 ${\it\rho}_{l}$
, the permeability
 $\boldsymbol{k}$
and the excess stress tensor
 ${\bf\sigma}$
, defined as the stress tensor of the mixture minus the liquid pressure (see Preziosi et al.
Reference Preziosi, Joseph and Beavers1996).
Illustrative description of the model consisting of a poroelastic material (dotted area) connecting a rigid body and a lubrication region (dashed; red online). The poroelastic material is axisymmetric with radius
 $r_{o}$
, height
 $h$
and external axial force
 $f_{e}$
acting on the rigid body.

3.2. Analysis of the poroelastic medium
The dynamics of a poroelastic medium saturated with a Newtonian incompressible liquid is governed by the conservation of mass of the solid,
 $$\begin{eqnarray}\frac{\partial {\it\Phi}}{\partial t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }({\it\Phi}\boldsymbol{v}_{s})=0,\end{eqnarray}$$
the conservation of mass of the liquid,
 $$\begin{eqnarray}-\frac{\partial {\it\Phi}}{\partial t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }[(1-{\it\Phi})\boldsymbol{v}_{l}]=0,\end{eqnarray}$$
Darcy’s law for the flow within the porous material,
 $$\begin{eqnarray}\boldsymbol{v}_{l}-\boldsymbol{v}_{s}=-\frac{\boldsymbol{k}}{(1-{\it\Phi}){\it\mu}}(\boldsymbol{{\rm\nabla}}p-{\it\rho}_{l}\boldsymbol{g}),\end{eqnarray}$$
and equation of the mixed momentum,
 $$\begin{eqnarray}{\it\rho}_{c}\left(\frac{\partial \boldsymbol{v}_{m}}{\partial t}+\boldsymbol{v}_{m}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{v}_{m}\right)=-\boldsymbol{{\rm\nabla}}p+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }{\bf\sigma}+[{\it\rho}_{s}{\it\Phi}+{\it\rho}_{l}(1-{\it\Phi})]\boldsymbol{g}.\end{eqnarray}$$
Here
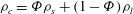 ${\it\rho}_{c}={\it\Phi}{\it\rho}_{s}+(1-{\it\Phi}){\it\rho}_{l}$
is the density of the mixture considered as a whole and
 $\boldsymbol{v}_{m}=[{\it\Phi}{\it\rho}_{s}\boldsymbol{v}_{s}+(1-{\it\Phi}){\it\rho}_{l}\boldsymbol{v}_{l}]/{\it\rho}_{c}$
is the mass average velocity (see Preziosi et al.
Reference Preziosi, Joseph and Beavers1996).
The relevant boundary conditions are no solid velocity at
 $z=0$
and external velocity function
 $\boldsymbol{v}_{e}(t)$
at
 $z=h(t)$
,
 $$\begin{eqnarray}\boldsymbol{v}_{s}(z=0)=0,\quad \boldsymbol{v}_{s}(z=h(t))=\boldsymbol{v}_{l}(z=h(t))=\boldsymbol{v}_{e}(t).\end{eqnarray}$$
The initial conditions are
 $$\begin{eqnarray}{\it\Phi}(t=0)={\it\Phi}_{i},\quad h(t=0)=h_{i}.\end{eqnarray}$$
Hereafter all normalized parameters are denoted by capital letters and characteristic values are denoted by asterisk superscripts. We define normalized coordinates
 $R$
,
 $Z$
and time
 $T$
,
 $$\begin{eqnarray}R=\frac{r}{r_{o}},\quad Z=\frac{z}{h^{\ast }},\quad T=\frac{t}{h^{\ast }/w^{\ast }},\end{eqnarray}$$
normalized liquid velocity
 $\boldsymbol{V}_{l}$
and pressure
 $P$
,
 $$\begin{eqnarray}\boldsymbol{V}_{l}=\frac{\boldsymbol{v}_{l}}{w^{\ast }},\quad P=\frac{p}{p^{\ast }},\end{eqnarray}$$
normalized solid velocity
 $\boldsymbol{V}_{s}$
, solid stress
 ${\it\bf\Sigma}$
and permeability
 $\boldsymbol{K}$
,
 $$\begin{eqnarray}\boldsymbol{V}_{s}=\frac{\boldsymbol{v}_{s}}{w^{\ast }},\quad {\it\bf\Sigma}=\frac{{\bf\sigma}}{{\bf\sigma}^{\ast }},\quad \boldsymbol{K}=\frac{\boldsymbol{k}}{k^{\ast }},\end{eqnarray}$$
and poroelastic height
 $H$
,
 $$\begin{eqnarray}H=\frac{h(t)}{h^{\ast }}.\end{eqnarray}$$
Here
 $h^{\ast }$
is the characteristic height,
 $w^{\ast }$
is the characteristic speed,
 $p^{\ast }$
is the characteristic pressure,
 ${\bf\sigma}^{\ast }$
is the characteristic axial stress and
 $k^{\ast }$
is the characteristic permeability.
Our analysis will focus on a thin geometry, defined as
 $$\begin{eqnarray}{\it\varepsilon}_{1}=\frac{h^{\ast }}{r_{o}}\ll 1.\end{eqnarray}$$
Substituting the normalized variables yields the leading-order form of (3.1)–(3.4) as
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\Phi}}{\partial T}+\frac{\partial }{\partial Z}({\it\Phi}W_{s})+O({\it\varepsilon}_{1})=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle -\frac{\partial {\it\Phi}}{\partial T}+\frac{\partial }{\partial Z}[(1-{\it\Phi})W_{l}]+O({\it\varepsilon}_{1})=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle W_{l}-W_{s}=-\frac{k^{\ast }p^{\ast }}{{\it\mu}w^{\ast }h^{\ast }}\frac{K_{zz}}{(1-{\it\Phi})}\frac{\partial P}{\partial Z}+O\left({\it\varepsilon}_{1},\frac{{\it\rho}_{l}gk_{0}}{{\it\mu}w^{\ast }}\right) & \displaystyle\end{eqnarray}$$
and
 $$\begin{eqnarray}\frac{\partial P}{\partial Z}=\frac{{\it\sigma}^{\ast }}{p^{\ast }}\frac{\partial {\it\Sigma}_{zz}}{\partial Z}+O\left({\it\varepsilon}_{1},\frac{{\it\rho}_{j}(w^{\ast })^{2}}{p^{\ast }},\frac{[{\it\rho}_{s}{\it\Phi}+{\it\rho}_{l}(1-{\it\Phi})]g}{p^{\ast }}\right),\end{eqnarray}$$
where
 ${\it\Sigma}_{zz}$
and
 $K_{zz}$
are the axial terms of
 ${\it\bf\Sigma}$
and
 $\boldsymbol{K}$
, respectively, and
 $W_{s}$
and
 $W_{l}$
are the axial solid and liquid speeds, respectively.
Following the previous works of Anderson (Reference Anderson2005), Siddique (Reference Siddique2009) and Siddique, Anderson & Bondarev (Reference Siddique, Anderson and Bondarev2009), the constitutive relationships for the permeability
 $k$
and stress
 ${\it\sigma}$
are approximated as
 $$\begin{eqnarray}k_{zz}=\frac{k_{0}}{{\it\Phi}},\quad {\it\sigma}=m({\it\Phi}_{r}-{\it\Phi}),\end{eqnarray}$$
where
 $k_{0}>0$
and
 $m>0$
are known constants defining the poroelastic material permeability and stiffness, respectively. Order of magnitude analysis of (3.15) and (3.16) yield
 $p^{\ast }={\it\sigma}^{\ast }=m$
and
 $k^{\ast }=k_{0}$
.
We define the scaled coordinate
 ${\it\Psi}=z/h(t)$
and formulate the problem according to Preziosi et al. (Reference Preziosi, Joseph and Beavers1996). Adding (3.13) and (3.12), integrating over
 $Z$
and using (3.5) we obtain
 $$\begin{eqnarray}W_{l}(1-{\it\Phi})+{\it\Phi}W_{s}=\frac{\partial H}{\partial T}.\end{eqnarray}$$
 $$\begin{eqnarray}W_{s}=\frac{\partial H}{\partial T}-\frac{mk_{0}}{{\it\mu}w^{\ast }h^{\ast }}\frac{1}{{\it\Phi}H(T)}\frac{\partial {\it\Phi}}{\partial {\it\Psi}}\end{eqnarray}$$
and
 $$\begin{eqnarray}W_{l}=\frac{\partial H}{\partial T}+\frac{mk_{0}}{{\it\mu}w^{\ast }h^{\ast }}\frac{1}{(1-{\it\Phi})H(T)}\frac{\partial {\it\Phi}}{\partial {\it\Psi}}.\end{eqnarray}$$
Combining (3.19) and (3.12) together with (3.15) yields
 $$\begin{eqnarray}\frac{\partial {\it\Phi}}{\partial T}+(1-{\it\Psi})\frac{\partial H}{\partial T}\frac{1}{H(T)}\frac{\partial {\it\Phi}}{\partial {\it\Psi}}=\frac{mk_{0}}{{\it\mu}w^{\ast }h^{\ast }}\frac{1}{H^{2}(T)}\frac{\partial ^{2}{\it\Phi}}{\partial {\it\Psi}^{2}}.\end{eqnarray}$$
We express the boundary conditions (3.5) in terms of solid fraction
 ${\it\Phi}$
as
 $$\begin{eqnarray}\frac{mk_{0}}{{\it\mu}w^{\ast }h^{\ast }}\frac{\partial {\it\Phi}}{\partial {\it\Psi}}=0,\quad {\it\Psi}=1,\end{eqnarray}$$
and
 $$\begin{eqnarray}\frac{mk_{0}}{{\it\mu}w^{\ast }h^{\ast }}\frac{\partial {\it\Phi}}{\partial {\it\Psi}}-H(T)\frac{\partial H}{\partial T}{\it\Phi}=0,\quad {\it\Psi}=0,\end{eqnarray}$$
where
 ${\it\mu}w^{\ast }h^{\ast }/mk_{0}$
can be interpreted as the ratio between the characteristic speed of the poroelastic problem,
 $w^{\ast }$
, and the characteristic speed of the viscous flow,
 $mk_{0}/{\it\mu}h^{\ast }$
.
3.3. Analysis of lubrication region
We denote by tildes the liquid velocity
 $\tilde{\boldsymbol{v}}_{l}=(\tilde{u} _{l},\tilde{w}_{l})$
in the lubrication region, where
 $\tilde{u} _{l}$
is the radial speed and
 $\tilde{w}_{l}$
is the axial speed. The governing equations in the lubrication region are the axisymmetric Stokes equations for Newtonian incompressible liquid,
 $$\begin{eqnarray}\boldsymbol{{\rm\nabla}}p={\it\mu}{\rm\nabla}^{2}\tilde{\boldsymbol{v}}_{l},\end{eqnarray}$$
and conservation of mass,
 $$\begin{eqnarray}\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\tilde{\boldsymbol{v}}_{l}=0.\end{eqnarray}$$
The relevant boundary conditions are gauge pressure
 $p=0$
at
 $r=r_{o}$
, symmetry
 $\partial p/\partial r=0$
at
 $r=0$
, no-slip and no-penetration
 $\tilde{\boldsymbol{v}}_{l}=0$
at the solid interface and mass-flux and pressure matching to the poroelastic region
 $\tilde{w}_{l}=(1-{\it\Phi})w_{l}$
at
 $z=0$
. The liquid slip at the boundary of the porous material,
 $z=0$
, is proportional to
 $\sqrt{k_{0}}\,\partial \tilde{u} _{l}/\partial z$
, where
 $\sqrt{k_{0}}$
is the characteristic length scale of the permeable material (Beavers & Joseph Reference Beavers and Joseph1967). We relate the characteristic roughness
 $\tilde{h}$
to average viscous resistance by defining
 $$\begin{eqnarray}\tilde{h}^{-3}=\frac{1}{A}\int _{A}h_{s}^{-3}\,\text{d}A,\end{eqnarray}$$
where
 $h_{s}$
is the local gap between the solid surface and the poroelastic surface and
 $A$
is a sufficiently large surface area on the
 $z$
plane. The normalized velocity
 $\tilde{U_{l}}$
,
 $\tilde{W_{l}}$
and
 $\tilde{Z}$
coordinate for the lubrication region are defined as
 $$\begin{eqnarray}\tilde{U_{l}}=\frac{u}{u^{\ast }},\quad \tilde{W_{l}}=\frac{\tilde{W_{l}}}{w^{\ast }},\quad \tilde{Z}=\frac{z}{\tilde{h}}.\end{eqnarray}$$
We require sufficiently small
 $k_{0}$
so that
 $$\begin{eqnarray}{\it\varepsilon}_{2}=\frac{k_{0}h^{\ast }}{\tilde{h}^{3}/12}\ll 1,\quad {\it\varepsilon}_{3}=\frac{u_{l}(Z=0)}{u^{\ast }}=\frac{\sqrt{k_{0}}}{h^{\ast }}\ll 1,\end{eqnarray}$$
representing the scaled pore size and the slip at the boundary of the poroelastic surface. For
 ${\it\varepsilon}_{3}\ll 1$
we require
 $\tilde{U} _{l}=0$
at
 $\tilde{Z}=0$
. (The lubrication region may also be modelled as a porous region of depth
 $h_{p}$
and radial permeability
 $k_{p}$
, where
 $\tilde{h}^{3}/12=k_{p}h_{p}$
.)
Substituting (3.26) into (3.23) and (3.24), an order-of-magnitude analysis yields
 $$\begin{eqnarray}u^{\ast }=\frac{w^{\ast }r_{o}}{\tilde{h}},\quad w^{\ast }=\frac{m\tilde{h}^{3}/12}{{\it\mu}r_{0}^{2}},\end{eqnarray}$$
and normalized equation (3.23) is thus
 $$\begin{eqnarray}\frac{\partial P}{\partial R}\sim \frac{1}{H_{s}^{3}}\int _{-H_{s}}^{0}\tilde{U_{l}}\,\text{d}\tilde{Z},\quad \frac{\partial P}{\partial \tilde{Z}}\sim 0,\end{eqnarray}$$
where
 $H_{s}=h_{s}/\tilde{h}$
is the local normalized gap. We substitute (3.29) into (3.24) and apply the boundary conditions
 $\tilde{W_{l}}=(1-{\it\Phi})W_{l}$
at
 $\tilde{Z}=0$
(flux matching between the lubrication region and the poroelastic region) and
 $\tilde{U_{l}}=\tilde{W_{l}}=0$
at the solid surface. Thus we obtain the pressure distribution in the lubrication region. Substituting into the variables of the poroelastic region and utilizing (3.25) yields
 $$\begin{eqnarray}P({\it\Psi}=0)\sim -(1-{\it\Phi}({\it\Psi}=0))W_{l}({\it\Psi}=0)\frac{1-R^{2}}{4}.\end{eqnarray}$$
3.4. Results
3.4.1. Governing equations
Substituting (3.28) into (3.20)–(3.22) yields
 $$\begin{eqnarray}\frac{mk_{0}}{{\it\mu}w^{\ast }h^{\ast }}=\frac{k_{0}h^{\ast }}{\tilde{h}^{3}/12}\frac{r_{o}^{2}}{(h^{\ast })^{2}}=\frac{{\it\varepsilon}_{2}}{{\it\varepsilon}_{1}^{2}}\end{eqnarray}$$
and the governing equation
 $$\begin{eqnarray}\frac{1}{H^{2}}\frac{\partial ^{2}{\it\Phi}}{\partial {\it\Psi}^{2}}-\frac{{\it\varepsilon}_{1}^{2}}{{\it\varepsilon}_{2}}\left[\frac{\partial {\it\Phi}}{\partial T}+(1-{\it\Psi})\frac{\partial H}{\partial T}\frac{1}{H}\frac{\partial {\it\Phi}}{\partial {\it\Psi}}\right]=0,\end{eqnarray}$$
with the boundary conditions
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\Phi}}{\partial {\it\Psi}}-\frac{{\it\varepsilon}_{1}^{2}}{{\it\varepsilon}_{2}}H\frac{\partial H}{\partial T}{\it\Phi}=0,\quad {\it\Psi}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\Phi}}{\partial {\it\Psi}}=0,\quad {\it\Psi}=1, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}{\it\Phi}={\it\Phi}_{i},\quad T=0.\end{eqnarray}$$
The liquid speed
 $W_{l}$
and solid speed
 $W_{s}$
are thus
 $$\begin{eqnarray}W_{s}=\frac{\partial H}{\partial T}-\frac{{\it\varepsilon}_{2}}{{\it\varepsilon}_{1}^{2}}\frac{1}{{\it\Phi}H(T)}\frac{\partial {\it\Phi}}{\partial {\it\Psi}},\quad W_{l}=\frac{\partial H}{\partial T}+\frac{{\it\varepsilon}_{2}}{{\it\varepsilon}_{1}^{2}}\frac{1}{(1-{\it\Phi})H(T)}\frac{\partial {\it\Phi}}{\partial {\it\Psi}}.\end{eqnarray}$$
Substituting (3.36) into (3.30) yields the gauge pressure at
 $Z=0$
:
 $$\begin{eqnarray}P(Z=0)=-(1-{\it\Phi}(0))\left(\frac{\partial H}{\partial T}+\frac{{\it\varepsilon}_{2}}{{\it\varepsilon}_{1}^{2}}\frac{1}{(1-{\it\Phi}(0))H}\frac{\partial {\it\Phi}(0)}{\partial {\it\Psi}}\right)\frac{1-R^{2}}{4}.\end{eqnarray}$$
Integration over
 $P(Z=0)$
will yield the total normal force applied by the liquid. The external force applied on the poroelastic material
 $F_{e}=f_{e}/mr_{o}^{2}$
(see figure 2) is balanced by the force applied by the solid surface (denoted hereafter as
 $F_{s}={\rm\pi}({\it\Phi}_{r}-{\it\Phi}({\it\Psi}=0))$
and normalized by
 $mr_{o}^{2}$
) and the force applied by the liquid gauge pressure at
 ${\it\Psi}=0$
. The force balance equation,
 $F_{e}=\int _{0}^{1}({\it\Sigma}_{zz}-P)2{\rm\pi}R\,\text{d}R$
, yields the expression for the external force:
 $$\begin{eqnarray}F_{e}={\rm\pi}({\it\Phi}_{r}-{\it\Phi}({\it\Psi}=0))+\frac{{\rm\pi}}{8}(1-{\it\Phi}(0))\left(\frac{\partial H}{\partial T}+\frac{{\it\varepsilon}_{2}}{{\it\varepsilon}_{1}^{2}}\frac{1}{(1-{\it\Phi}(0))H}\frac{\partial {\it\Phi}(0)}{\partial {\it\Psi}}\right).\end{eqnarray}$$
For the limit
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}\ll 1$
we define the asymptotic expansion
 $$\begin{eqnarray}{\it\Phi}={\it\Phi}_{0}+\left(\frac{{\it\varepsilon}_{1}^{2}}{{\it\varepsilon}_{2}}\right){\it\Phi}_{1}+\left(\frac{{\it\varepsilon}_{1}^{2}}{{\it\varepsilon}_{2}}\right)^{2}{\it\Phi}_{2}+O\left[\left(\frac{{\it\varepsilon}_{1}^{2}}{{\it\varepsilon}_{2}}\right)^{3}\right].\end{eqnarray}$$
(We focus on the limit
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}\ll 1$
since it agrees with the characteristic physical parameters of frogs’ toe pads; see § 3.4.4.) We substitute (3.39) into (3.32)–(3.35). The leading-order problem yields that
 ${\it\Phi}_{0}(T)$
is a function of time only. The first-order terms of (3.32) and (3.34) yield
 $$\begin{eqnarray}{\it\Phi}_{1}=H^{2}\frac{\partial {\it\Phi}_{0}}{\partial T}\left(\frac{{\it\Psi}^{2}}{2}-{\it\Psi}\right)+C_{1}(T).\end{eqnarray}$$
Substituting
 ${\it\Phi}_{0}$
and
 ${\it\Phi}_{1}$
into the order
 $O({\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2})$
boundary condition at
 ${\it\Psi}=0$
, equation (3.33) yields an ordinary differential equation with respect to time:
 $$\begin{eqnarray}\frac{\partial {\it\Phi}_{0}}{\partial T}+\frac{\partial H}{\partial T}\frac{{\it\Phi}_{0}}{H}=0.\end{eqnarray}$$
Solving (3.41) with (3.35) yields
 ${\it\Phi}_{0}={\it\Phi}_{i}H(0)/H(T)$
. We determine
 $C_{1}(T)$
from the order
 $O[({\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2})^{2}]$
equation (3.32),
 $$\begin{eqnarray}\frac{\partial ^{2}{\it\Phi}_{2}}{\partial {\it\Psi}^{2}}=H^{2}\frac{\partial {\it\Phi}_{1}}{\partial T}+(1-{\it\Psi})\frac{\partial H}{\partial T}H\frac{\partial {\it\Phi}_{1}}{\partial {\it\Psi}},\end{eqnarray}$$
and the
 $O[({\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2})^{2}]$
boundary and initial conditions. Substituting (3.40) into (3.42) and applying (3.34), we obtain an ordinary differential equation from the boundary condition at
 ${\it\Psi}=0$
, similarly to (3.41), for the order
 $O({\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2})$
:
 $$\begin{eqnarray}\frac{\partial C_{1}}{\partial T}+\frac{\partial H}{\partial T}\frac{1}{H}C_{1}=-\frac{1}{3}\frac{{\it\Phi}_{i}H(0)}{H}\frac{\partial }{\partial T}\left(H\frac{\partial H}{\partial T}\right).\end{eqnarray}$$
Applying (3.35) we solve (3.43) and obtain
 $$\begin{eqnarray}C_{1}=-\frac{H(0)}{3}{\it\Phi}_{i}\frac{\partial H}{\partial T}.\end{eqnarray}$$
Thus
 ${\it\Phi}$
to order
 $O({\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2})$
is
 $$\begin{eqnarray}\frac{{\it\Phi}}{{\it\Phi}_{i}}\sim \frac{H(0)}{H}+\frac{{\it\varepsilon}_{1}^{2}}{{\it\varepsilon}_{2}}H(0)\frac{\partial H}{\partial T}\left({\it\Psi}-\frac{{\it\Psi}^{2}}{2}-\frac{1}{3}\right),\end{eqnarray}$$
and from (3.35) we obtain the requirement
 $\partial H(0)/\partial T=0$
in order to satisfy the spatially uniform initial condition.
3.4.2. Externally controlled
 $H$
for
${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}\ll 1$


Based on (3.45) and (3.38) we can calculate
 $F_{e}$
required to achieve an arbitrary
 $H(T)$
. After calculating
 $H(T)$
, exact solutions of the solid fraction
 ${\it\Phi}$
, fluid velocity
 $W_{l}$
, solid velocity
 $W_{s}$
and internal stress
 ${\it\Sigma}$
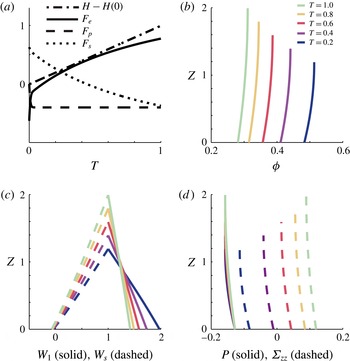
can be obtained from (3.45) and (3.36)–(3.38). Figure 3 presents the case of
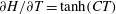 $\partial H/\partial T=\tanh (CT)$
, where
 $C=100$
, and thus
 $\partial H/\partial T\approx 1$
for
 $T>0.02$
. The initial uniform solid fraction of the poroelastic medium is
 ${\it\Phi}_{i}=0.6$
, relaxed solid fraction is
 ${\it\Phi}_{r}=0.4$
, and
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}=0.1$
. Panel (a) presents the change in poroelastic layer height
 $H-1$
(dash-dotted), external force
 $F_{e}$
(solid), total force by the liquid pressure
 $F_{p}$
(dashed) and force applied by the solid surface
 $F_{s}$
(dotted). The total force by the liquid pressure
 $F_{p}$
becomes nearly constant from
 $T\approx 0.03$
(as
 $\partial H/\partial T\rightarrow 1$
), while
 $F_{s}$
decreases in time. The external force is initially negative and prevents the compressed poroelastic material from expanding more rapidly than the required
 $\partial H/\partial T=1$
. From
 $T\approx 0.1,~F_{e}$
is positive and acts to increase
 $\partial H/\partial T$
. In panels (b–d) the various curves (blue, purple, red, yellow and green online) mark normalized time
 $T=0.2$
, 0.4, 0.6, 0.8 and 1, respectively. Panel (b) presents solid fraction
 ${\it\Phi}$
versus
 $Z$
for various times, showing the decrease of
 ${\it\Phi}$
with time and as
 $Z\rightarrow 0$
. Panel (c) presents liquid speed
 $W_{l}$
(solid) and solid speed
 $W_{s}$
(dashed) versus
 $Z$
for various times. Both speeds are approximately linear with
 $Z$
with gradients decreasing with time. Panel (d) presents pressure
 $P$
(solid) and axial stress
 ${\it\Sigma}_{zz}$
(dashed) versus
 $Z$
for various times. The average pressure
 $P$
is approximately constant, owing to the uniform liquid mass flux into the poroelastic material. The axial stress increases with time because of the forced deformation of the poroelastic material. Owing to the initial compression, the axial stress is negative until
 $T\approx 0.4$
and then becomes positive as a result of stretching by the external force.
Configuration with speed
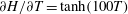 $\partial H/\partial T=\tanh (100T)$
(effectively
 $\partial H/\partial T\approx 1$
for
 $T>0.02$
). The initial uniform solid fraction of the poroelastic medium is
 ${\it\Phi}_{i}=0.6$
, relaxed solid fraction is
 ${\it\Phi}_{r}=0.4$
and
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}=0.1$
. (a) Change in gap
 $H-1$
(dash-dotted), external required force
 $F_{e}$
(solid), total force by the liquid pressure
 $F_{p}$
(dashed) and force applied by the solid surface
 $F_{s}$
(dotted); (b) solid fraction
 ${\it\Phi}$
, (c) liquid speed
 $W_{l}$
(solid) and solid speed
 $W_{s}$
(dashed) and (d) pressure
 $P$
(solid) and axial stress
 ${\it\Sigma}_{zz}$
versus
 $Z$
for various normalized times
 $T=0.2$
, 0.4, 0.6, 0.8 and 1 (blue, purple, red, yellow and green online, respectively).

3.4.3. Externally controlled
$F_{e}$
for
${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}\ll 1$


Configuration with initial compression and a sudden release at
 $T=0$
with
 $F_{e}=0$
. The initial uniform solid fraction of the poroelastic medium is
 ${\it\Phi}_{i}=0.6$
, relaxed solid fraction is
 ${\it\Phi}_{r}=0.4$
and
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}=0.1$
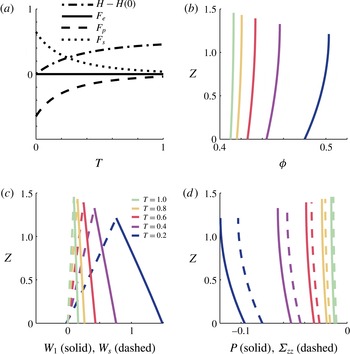
. (a) Change in poroelastic layer height
 $H-1$
(dash-dotted), external required force
 $F_{e}$
(solid), total force by the liquid pressure
 $F_{p}$
(dashed) and force applied by the solid surface
 $F_{s}$
(dotted); (b) solid fraction
 ${\it\Phi}$
, (c) liquid speed
 $W_{l}$
(solid) and solid speed
 $W_{s}$
(dashed) and (d) pressure
 $P$
(solid) and stress
 ${\it\Sigma}_{zz}$
versus
 $Z$
for various normalized times
 $T=0.2$
, 0.4, 0.6, 0.8 and 1 (blue, purple, red, yellow and green online, respectively).

We apply (3.45) with (3.38) to obtain
 $H$
as a function of the external force acting on the poroelastic material for
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}\ll 1$
,
 $$\begin{eqnarray}F_{e}={\rm\pi}\left({\it\Phi}_{r}-{\it\Phi}_{i}\frac{H(0)}{H}\right)+\frac{{\rm\pi}}{8}\frac{\partial H}{\partial T}.\end{eqnarray}$$
For constant
 $F_{e}$
, separation of variables yields an implicit solution of
 $H(T)$
,
 $$\begin{eqnarray}T=\frac{{\rm\pi}}{8}\left[\frac{H-H(0)}{F_{e}-{\rm\pi}{\it\Phi}_{r}}-\frac{{\rm\pi}{\it\Phi}_{i}H(0)}{(F_{e}-{\rm\pi}{\it\Phi}_{r})^{2}}\ln \left(\frac{H(F_{e}-{\rm\pi}{\it\Phi}_{r})-{\rm\pi}{\it\Phi}_{i}H(0)}{H(0)(F_{e}-{\rm\pi}{\it\Phi}_{r})-{\rm\pi}{\it\Phi}_{i}H(0)}\right)\right].\end{eqnarray}$$
Figure 4 presents the case of initial compression of the poroelastic material, with sudden release
 $F_{e}=0$
, solved by (3.47). For
 $F_{e}=0$
, exact solutions of the solid fraction
 ${\it\Phi}$
, fluid velocity
 $W_{l}$
, solid velocity
 $W_{s}$
and internal stress
 ${\it\Sigma}_{zz}$
are calculated from (3.45) and (3.36)–(3.38). The initial uniform solid fraction of the poroelastic medium is
 ${\it\Phi}_{i}=0.6$
, relaxed solid fraction is
 ${\it\Phi}_{r}=0.4$
, initial height is
 $H(0)=1$
and
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}=0.1$
. Panel (a) presents the change in poroelastic layer height
 $H-1$
(dash-dotted), external required force
 $F_{e}$
(solid), total force by the liquid pressure
 $F_{p}$
(dashed) and force applied by the solid surface
 $F_{s}$
(dotted). The absolute value of the force applied by the liquid pressure
 $F_{p}$
decreases while the sign of
 $F_{p}$
is negative for all
 $T$
. The force applied by the solid surface
 $F_{s}$
decreases in time and is positive for all
 $T$
. The speed
 $\partial H/\partial T$
is maximal at
 $T=0$
and decreases with time as the configuration reaches a steady balance. In panels (b–d) the various curves (blue, purple, red, yellow and green online) mark normalized time
 $T=0.2$
, 0.4, 0.6, 0.8 and 1, respectively. Panel (b) presents solid fraction
 ${\it\Phi}$
versus
 $Z$
for various times, showing a decrease of
 ${\it\Phi}$
with time and nearly constant values with
 $Z$
. Panel (c) presents liquid speed
 $W_{l}$
(solid) and solid speed
 $W_{s}$
(dashed) versus
 $Z$
for various times. Both speeds are approximately linear with
 $Z$
with gradients decreasing with time. Panel (d) presents pressure
 $P$
(solid) and axial stress
 ${\it\Sigma}_{zz}$
(dashed) versus
 $Z$
for various times. Since no external forces act on the system, the dominant balance is between pressure
 $P$
and axial stress and thus
 $P\approx {\it\Sigma}_{zz}$
. The magnitude of both parameters decreases with time as the system approaches steady balance.
3.4.4. Characteristic values of frogs’ toe pads and adhesion time estimation
We estimate, based on existing works, the order of magnitude of the relevant physical properties of frogs’ toe pads. We focus on torrent frogs because of their ability to keep adhesion underwater and thus without capillary forces. Based on Federle et al. (Reference Federle, Barnes, Baumgartner, Drechsler and Smith2006) and Endlein et al. (Reference Endlein, Barnes, Samuel, Crawford, Biaw and Grafe2013a
), we obtain that the total toe pad area is
 $10^{-4}~\text{m}^{2}$
, the number of toes is 18, yielding individual toe pad radius of
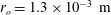 $r_{o}=1.3\times 10^{-3}~\text{m}$
(assuming circular toe pads), the frog mass is
 $2.7\times 10^{-3}~\text{kg}$
, the viscosity of the mucus is
 ${\it\mu}\approx 10^{-3}~\text{Pa}~\text{s}$
, the toe pad height is
 $h_{r}=10^{-5}~\text{m}$
, and the permeability of the frogs’ toe pad is calculated via
 $k_{0}\approx d_{p}^{2}/4$
, where
 $d_{p}=10^{-7}~\text{m}$
is the characteristic length scale of the pores. We examine various values of the characteristic gap in the lubrication region
 $\tilde{h}$
and the stiffness parameter
 $m$
. For
 $\tilde{h}=10^{-6}~\text{m}$
, we obtain
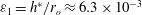 ${\it\varepsilon}_{1}=h^{\ast }/r_{o}\approx 6.3\times 10^{-3}$
and
 ${\it\varepsilon}_{2}=k_{0}h^{\ast }/12\tilde{h}^{3}=0.1$
, thus
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}\approx 4\times 10^{-4}$
.
Slip will occur when
 $f_{t}\geqslant f_{s}{\it\mu}_{s}$
, where
 $f_{s}$
is the dimensional normal force acting on the surface,
 ${\it\mu}_{s}$
is the friction coefficient and
 $f_{t}$
is a tangential force (see figure 5
a). Utilizing
 $F_{s}={\rm\pi}({\it\Phi}_{r}-{\it\Phi}({\it\Psi}=0))$
, we can obtain
 ${\it\Phi}_{s}$
, the solid fraction at
 ${\it\Psi}=0$
for which slip will occur,
 $$\begin{eqnarray}{\it\Phi}_{s}={\it\Phi}_{r}-\frac{1}{{\it\mu}_{s}}\frac{f_{t}}{m{\rm\pi}r_{o}^{2}}.\end{eqnarray}$$
Substituting (3.45) into (3.48) yields
 $H_{s}$
, the height of the poroelastic medium when slip occurs,
 $$\begin{eqnarray}H_{s}=\frac{{\it\Phi}_{i}}{{\it\Phi}_{s}},\end{eqnarray}$$
and substituting (3.49) into (3.47) yields the adhesion time
 $t_{a}$
.
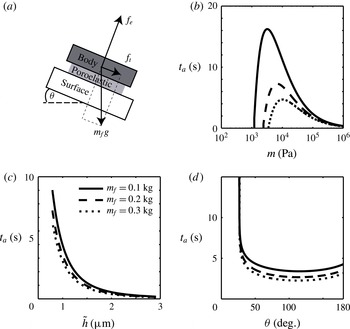
Figure 5 presents the dimensional adhesion time
 $t_{a}$
for various configurations and parameters. Panel (a) presents the slope angle
 ${\it\theta}$
and the normal forces. The normal force is
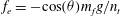 $f_{e}=-\!\cos ({\it\theta})m_{f}g/n_{t}$
and the tangential force is
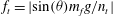 $f_{t}=|\sin ({\it\theta})m_{f}g/n_{t}|$
, where
 $m_{f}$
is the mass of the frog,
 $g$
is gravity and
 $n_{t}$
is the number of frog toes. Panels (b–c) present the adhesion time
 $t_{a}$
for different frog masses of
 $10^{-3}~\text{kg}$
(dashed),
 $2\times 10^{-3}~\text{kg}$
(dashed) and
 $3\times 10^{-3}~\text{kg}$
(dotted) at
 ${\it\theta}=60^{\circ }$
. Panel (b) presents the adhesion time
 $t_{a}$
versus stiffness parameter
 $m$
for
 ${\it\Phi}_{i}=0.85$
and
 ${\it\theta}=60^{\circ }$
. For stiffness parameter below a critical value (
 $m\approx 10^{3}~\text{Pa}$
), no adhesion is created. With increasing
 $m$
, a maximum of adhesion time is presented, as well as a monotonic decrease in adhesion time as
 $m\rightarrow \infty$
. Panel (c) presents the adhesion time
 $t_{a}$
versus characteristic gap in the lubrication region
 $\tilde{h}$
(defined by (3.25)), for
 ${\it\theta}=60^{\circ }$
and
 $m=5\times 10^{5}~\text{Pa}$
. A monotonic increase in adhesion time with decreasing
 $\tilde{h}$
is observed. Panel (d) presents the adhesion time versus slope angle
 ${\it\theta}$
for
 ${\it\Phi}_{i}=0.85$
and
 $m=5\times 10^{5}~\text{Pa}$
. Below a critical minimal value of
 ${\it\theta}$
, steady adhesion is achieved. With increasing
 ${\it\theta}$
, there is a decrease in the adhesion time until a minimum value, and then a moderate maximum at
 ${\it\theta}=180^{\circ }$
. In all cases we observe a monotonic increase in adhesion time with reduction of frog mass.
Adhesion time (time until tangential slip occurs)
 $t_{a}$
for various physical parameters: (a) the slope angle
 ${\it\theta}$
and the normal
 $f_{e}$
and tangential
 $f_{t}$
forces: (b) adhesion time
 $t_{a}$
versus the stiffness of the poroelastic material
 $m$
for
 ${\it\theta}=60^{\circ }$
and
 ${\it\Phi}_{i}=0.85$
; (c) adhesion time
 $t_{a}$
versus the initial solid fraction
 ${\it\Phi}_{i}$
(initial compression) for
 ${\it\theta}=60^{\circ }$
and
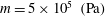 $m=5\times 10^{5}~(\text{Pa})$
; (d) adhesion time
 $t_{a}$
versus slope angle
 ${\it\theta}$
for
 ${\it\Phi}_{i}=0.85$
and
 $m=5\times 10^{5}~(\text{Pa})$
. Frog masses of
 $10^{-3}~\text{kg}$
(solid),
 $2\times 10^{-3}~\text{kg}$
(dashed) and
 $3\times 10^{-3}~\text{kg}$
(dotted) are presented. In all cases
 ${\it\Phi}_{r}=0.7$
.

4. Concluding remarks
In this work, we have suggested viscous–elastic interaction as being a mechanism to explain the adhesion of frogs’ toe pads. We applied a poroelastic model for the toe pad and a lubrication approximation for the flow between the toe pad and the solid surface. We obtained a governing equation for the solid fraction, which can be solved and then applied to obtain the solid stress, solid velocity, liquid pressure and liquid velocity. The viscous–elastic interaction was shown to be able to create temporary adhesion, even in the absence of capillary forces, and the adhesion time was estimated for physical parameters chosen from an order-of-magnitude estimation of frogs’ toe pads. A maximum for the adhesion time was observed with regard to
 $m$
, the stiffness parameter of the poroelastic medium, and a minimum with regard to the slope angle of the surface. The time-dependent nature of viscous–elastic adhesion is in agreement with the periodic repositioning of frogs’ toe pads during adhesion to surfaces. This analysis focused on a single toe pad; however, the dynamics of a complete frog includes multiple toe pads, which are repositioned at different times. Thus the computed adhesion time
 $t_{a}$
representing the time a single toe pad is connected to a surface may differ significantly from the adhesion time of the entire frog.
Acknowledgement
This research was supported by the Israel Science Foundation (grant 818/13).
Appendix A. Dimensional equations and boundary conditions
The dimensional governing equation for
 ${\it\Phi}$
, the solid fraction, is
 $$\begin{eqnarray}\frac{\partial {\it\Phi}}{\partial t}+\frac{\partial }{\partial z}\left[{\it\Phi}\left(\frac{\partial h}{\partial t}-\frac{mk_{0}}{{\it\mu}}\frac{\partial {\it\Phi}}{\partial z}\right)\right]=0,\end{eqnarray}$$
with the dimensional boundary conditions
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\Phi}}{\partial z}-\frac{{\it\mu}}{mk_{0}}\frac{\partial h}{\partial t}{\it\Phi}=0,\quad z=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\Phi}}{\partial z}=0,\quad z=h(t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}{\it\Phi}={\it\Phi}_{i},\quad t=0.\end{eqnarray}$$
Here the parameters
 $k_{0}$
,
 $m$
and
 ${\it\Phi}_{r}$
representing permeability, stiffness parameter and relaxed solid fraction, respectively, are known constants defining the properties of the poroelastic medium by the relations (following Anderson Reference Anderson2005; Siddique Reference Siddique2009; Siddique et al.
Reference Siddique, Anderson and Bondarev2009)
 $$\begin{eqnarray}k_{zz}=\frac{k_{0}}{{\it\Phi}},\quad {\it\sigma}=m({\it\Phi}_{r}-{\it\Phi}).\end{eqnarray}$$
The dimensional liquid speed
 $w_{l}$
and solid speed
 $w_{s}$
are
 $$\begin{eqnarray}w_{s}=\frac{\partial h}{\partial t}-\frac{mk_{0}}{{\it\mu}(1-{\it\Phi})}\frac{\partial {\it\Phi}}{\partial z}\end{eqnarray}$$
and
 $$\begin{eqnarray}w_{l}=\frac{\partial h}{\partial t}+\frac{mk_{0}}{{\it\mu}{\it\Phi}}\frac{\partial {\it\Phi}}{\partial z}.\end{eqnarray}$$
The dimensional gauge pressure at
 $z=0$
is
 $$\begin{eqnarray}p(z=0)=-3\frac{{\it\mu}r_{o}^{2}}{\tilde{h}^{3}}(1-{\it\Phi}(0))\left(\frac{\partial h}{\partial t}+\frac{mk_{0}}{{\it\mu}(1-{\it\Phi}(0))}\frac{\partial {\it\Phi}(0)}{\partial z}\right)\left(1-\frac{r^{2}}{r_{o}^{2}}\right).\end{eqnarray}$$
The dimensional force balance equation of the poroelastic medium is
 $$\begin{eqnarray}f_{e}=\frac{3{\rm\pi}}{2}\frac{{\it\mu}r_{o}^{2}}{\tilde{h}^{3}}(1-{\it\Phi}(0))\left(\frac{\partial h}{\partial t}+\frac{mk_{0}}{{\it\mu}(1-{\it\Phi}(0))}\frac{\partial {\it\Phi}(0)}{\partial z}\right)-m{\rm\pi}r_{o}^{2}({\it\Phi}(z=0)-{\it\Phi}_{r}),\end{eqnarray}$$
where
 $f_{e}$
is the external force. Slip occurs when
 $f_{t}>{\it\mu}_{s}\,f_{s}$
, where
 $f_{s}$
given by
 $f_{s}=m{\rm\pi}r_{o}^{2}({\it\Phi}(z=0)-{\it\Phi}_{r})$
is the normal force applied by the solid fraction of the poroelastic material and
 ${\it\mu}_{s}$
is the friction coefficient.
For
 ${\it\varepsilon}_{1}^{2}/{\it\varepsilon}_{2}\rightarrow 0$
we obtain the relation between
 ${\it\Phi}$
and
 $h$
as
 $$\begin{eqnarray}\frac{{\it\Phi}}{{\it\Phi}_{i}}\sim \frac{h(0)}{h}+\frac{{\it\mu}h(0)}{mk_{0}}\frac{\partial h}{\partial t}\left(\frac{z}{h}-\frac{1}{2}\frac{z^{2}}{h^{2}}-\frac{1}{3}\right).\end{eqnarray}$$