Based on a review of neurophysiological and behavioural evidence regarding the encoding of three-dimensional space in biological agents, Jeffery et al. argue for a bicoded map in which height information is available and used but not fully integrated with information from the horizontal dimensions in the cognitive map. We propose an alternative hypothesis, namely an augmented topological map with “semi-metric” properties that under certain circumstances will give rise to a representation which appears to be bicoded but is based on the same principles of spatial encoding operating in all three dimensions.
As an alternative to a metric representation, roboticists (Kuipers et al. Reference Kuipers, Browning, Gribble, Hewett and Remolina2000; Wyeth & Milford Reference Wyeth and Milford2009) have found that a topological representation suffices for robots to map and navigate planar environments. In these experiments, a graph representation, with nodes corresponding to distinct places and edges to specific motor programs, enables the robot to follow a path from one distinct place to another. To also allow the capability of executing shortcuts, this graph representation is augmented with metric information. Sensor-based estimates of travelled distance and travel direction associated with the edges allow assignment of metric coordinates to the nodes in the graph. These estimates will initially be unreliable. However, a mechanism as described by Wyeth and Milford (Reference Wyeth and Milford2009) corrects the metric coordinate estimates for the graph nodes when the agent returns to a previously visited distinct place. As a consequence, this representation converges to a “semi-metric” map. This differs from a real metric map in that the reliability of the metric information associated with the nodes varies across the graph. For sparsely connected subgraphs, for example less-travelled parts of the environment, the metric information can be unreliable. For highly interconnected subgraphs – for example, well-explored parts of the environment – the metric information can be used for optimizing paths: for instance, in calculating shortcuts.
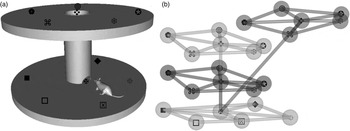
We propose that such a scheme can be extended to three dimensions: the nodes represent three-dimensional positions, and the edges the three-dimensional motor programs that move the agent from one position (i.e., sensorially distinct place) to another. If the environment allows multiple three-dimensional paths from one place to another, a “semi-metric” three-dimensional map would result. Elsewhere we have described a mechanical analogue (Veelaert & Peremans Reference Veelaert and Peremans1999) to model this process, in which we map the nodes in the graph onto spherical joints and the edges onto elastic rods. To represent both the uncertainty about the actual distance travelled and the direction of travel between the distinct places represented by the nodes, both the lengths of the rods and their orientations can vary (see Fig. 1). The rigidity of the resulting mechanical construction tells us whether all nodes are at well-defined positions relative to one another. Whenever particular subparts of the mechanical construction can still move relative to one another, this indicates that the corresponding parts of space are not well defined with respect to each other. However, if the subparts of the mechanical construction are rigid, relative positions within those parts of space can be fully defined.
Figure 1.
(a) Two-layered environment with marked distinct places; (b) three hypothetical representations of (a), where green = accurate travelled distance and orientation estimates, blue = inaccurate travelled distance estimate, and red = inaccurate travelled distance and orientation estimates.
Multilayer environments modeled with this representation result in a discrete set of highly interconnected subgraphs, one for each layer, connected together by a small number of isolated links. The isolated links correspond to the few paths that can be followed to go from one layer to another; for example, a staircase in a building. As the subgraphs are connected by a few links only, they can be metrically related to each other but the uncertainty on this relationship is higher than that between distinct places at the same layer. The metric representations of the different layers are only partially registered. In terms of our mechanical analogue, the constructions representing the individual layers are rigid, but these rigid substructures are linked to one another through a few links only, allowing them to move relative to each other as illustrated in Figure 1.
From the mechanical analogue, it is clear that the extent to which the augmented topological representation of space could act as a metric representation – that is, give rise to a rigid mechanical construction – depends on the interconnectivity of the nodes in the graph. One factor that determines this interconnectivity is whether the environment provides many opportunities for following different closed-loop paths that return to already-visited distinct places. Furthermore, given an environment providing many such opportunities, whether a highly interconnected graph would actually be constructed also depends on the movement patterns of the mapping agent. For example, the rats in the vertical plane maze seem to prefer movement patterns that extensively explore horizontal layers, only sparsely interspersed with short movements up or down the vertical dimension. Such a movement pattern gives rise to a set of highly interconnected subgraphs linked together by a few isolated links, similar to that of a multilayer environment. Hence, to really test whether the augmented topological representation (and the mechanism by which a three-dimensional “semi-metric” representation arises from it) corresponds with the actual cognitive map as implemented in mammalian brains, the experimental agents should be able to treat all spatial dimensions equivalently.
We propose that bats are a promising animal model for such a study, as they live in a true three-dimensional environment and have the motor capabilities to follow arbitrary three-dimensional paths through this environment. In particular, the spatial memory and orientation of nectar-feeding bats using both visual and echo-acoustic environment sensing have already been investigated in a series of studies (Thiele & Winter Reference Thiele and Winter2005; Winter et al. Reference Winter, von Merten and Kleindienst2004). Interestingly, Winter and Stich (Reference Winter and Stich2005) note that the hippocampus of nectar-feeding glossophagine bats is 50–100% larger in size than that of insectivorous members of the same family (Phyllostomidae). Although the reported results do not show evidence that these animals treat vertical and horizontal dimensions differently, more specific experiments are necessary, as the ones described were not aimed at finding out the nature of the bats' cognitive map.





Based on a review of neurophysiological and behavioural evidence regarding the encoding of three-dimensional space in biological agents, Jeffery et al. argue for a bicoded map in which height information is available and used but not fully integrated with information from the horizontal dimensions in the cognitive map. We propose an alternative hypothesis, namely an augmented topological map with “semi-metric” properties that under certain circumstances will give rise to a representation which appears to be bicoded but is based on the same principles of spatial encoding operating in all three dimensions.
As an alternative to a metric representation, roboticists (Kuipers et al. Reference Kuipers, Browning, Gribble, Hewett and Remolina2000; Wyeth & Milford Reference Wyeth and Milford2009) have found that a topological representation suffices for robots to map and navigate planar environments. In these experiments, a graph representation, with nodes corresponding to distinct places and edges to specific motor programs, enables the robot to follow a path from one distinct place to another. To also allow the capability of executing shortcuts, this graph representation is augmented with metric information. Sensor-based estimates of travelled distance and travel direction associated with the edges allow assignment of metric coordinates to the nodes in the graph. These estimates will initially be unreliable. However, a mechanism as described by Wyeth and Milford (Reference Wyeth and Milford2009) corrects the metric coordinate estimates for the graph nodes when the agent returns to a previously visited distinct place. As a consequence, this representation converges to a “semi-metric” map. This differs from a real metric map in that the reliability of the metric information associated with the nodes varies across the graph. For sparsely connected subgraphs, for example less-travelled parts of the environment, the metric information can be unreliable. For highly interconnected subgraphs – for example, well-explored parts of the environment – the metric information can be used for optimizing paths: for instance, in calculating shortcuts.
We propose that such a scheme can be extended to three dimensions: the nodes represent three-dimensional positions, and the edges the three-dimensional motor programs that move the agent from one position (i.e., sensorially distinct place) to another. If the environment allows multiple three-dimensional paths from one place to another, a “semi-metric” three-dimensional map would result. Elsewhere we have described a mechanical analogue (Veelaert & Peremans Reference Veelaert and Peremans1999) to model this process, in which we map the nodes in the graph onto spherical joints and the edges onto elastic rods. To represent both the uncertainty about the actual distance travelled and the direction of travel between the distinct places represented by the nodes, both the lengths of the rods and their orientations can vary (see Fig. 1). The rigidity of the resulting mechanical construction tells us whether all nodes are at well-defined positions relative to one another. Whenever particular subparts of the mechanical construction can still move relative to one another, this indicates that the corresponding parts of space are not well defined with respect to each other. However, if the subparts of the mechanical construction are rigid, relative positions within those parts of space can be fully defined.
(a) Two-layered environment with marked distinct places; (b) three hypothetical representations of (a), where green = accurate travelled distance and orientation estimates, blue = inaccurate travelled distance estimate, and red = inaccurate travelled distance and orientation estimates.
Multilayer environments modeled with this representation result in a discrete set of highly interconnected subgraphs, one for each layer, connected together by a small number of isolated links. The isolated links correspond to the few paths that can be followed to go from one layer to another; for example, a staircase in a building. As the subgraphs are connected by a few links only, they can be metrically related to each other but the uncertainty on this relationship is higher than that between distinct places at the same layer. The metric representations of the different layers are only partially registered. In terms of our mechanical analogue, the constructions representing the individual layers are rigid, but these rigid substructures are linked to one another through a few links only, allowing them to move relative to each other as illustrated in Figure 1.
From the mechanical analogue, it is clear that the extent to which the augmented topological representation of space could act as a metric representation – that is, give rise to a rigid mechanical construction – depends on the interconnectivity of the nodes in the graph. One factor that determines this interconnectivity is whether the environment provides many opportunities for following different closed-loop paths that return to already-visited distinct places. Furthermore, given an environment providing many such opportunities, whether a highly interconnected graph would actually be constructed also depends on the movement patterns of the mapping agent. For example, the rats in the vertical plane maze seem to prefer movement patterns that extensively explore horizontal layers, only sparsely interspersed with short movements up or down the vertical dimension. Such a movement pattern gives rise to a set of highly interconnected subgraphs linked together by a few isolated links, similar to that of a multilayer environment. Hence, to really test whether the augmented topological representation (and the mechanism by which a three-dimensional “semi-metric” representation arises from it) corresponds with the actual cognitive map as implemented in mammalian brains, the experimental agents should be able to treat all spatial dimensions equivalently.
We propose that bats are a promising animal model for such a study, as they live in a true three-dimensional environment and have the motor capabilities to follow arbitrary three-dimensional paths through this environment. In particular, the spatial memory and orientation of nectar-feeding bats using both visual and echo-acoustic environment sensing have already been investigated in a series of studies (Thiele & Winter Reference Thiele and Winter2005; Winter et al. Reference Winter, von Merten and Kleindienst2004). Interestingly, Winter and Stich (Reference Winter and Stich2005) note that the hippocampus of nectar-feeding glossophagine bats is 50–100% larger in size than that of insectivorous members of the same family (Phyllostomidae). Although the reported results do not show evidence that these animals treat vertical and horizontal dimensions differently, more specific experiments are necessary, as the ones described were not aimed at finding out the nature of the bats' cognitive map.