



1. Introduction
Let us consider a (one-sided) linear nonautonomous difference equation given by

as well as its nonlinear perturbation

where $A_n:X\to X$ , $n\in \mathbb {N}$
 is a sequence of invertible bounded linear operators acting on a Banach space $X$
 and $f_n: X\to X$
 , $n\in \mathbb {N}$
 is a sequence of (nonlinear) maps. In this note we are interested in describing sufficient conditions under which the systems (1.1) and (1.2) are topologically conjugated, meaning that there exists a sequence of homeomorphisms $H_n\colon X\to X$
 , $n\in \mathbb {N}$
 mapping the trajectories of (1.1) into trajectories of (1.2). Whenever such conjugacies exist, many important dynamical properties of the nonlinear system (1.2) can be obtained by studying the linear system (1.1), which in general is much easier to deal with.
Linearization problems, as the one described above, have a long history. As cornerstones of this theory (dealing with the case of autonomous dynamics), we refer to the works of Grobman [Reference Grobman16, Reference Grobman17] and Hartman [Reference Hartman18–Reference Hartman20]. The first linearization results dealing with the case of infinite-dimensional dynamics are due to Palis [Reference Palis23] and Pugh [Reference Pugh26]. The problem of formulating sufficient conditions under which the conjugacy exhibits higher regularity properties was first considered in the pioneering works of Sternberg [Reference Sternberg28, Reference Sternberg29].
The first nonautonomous version of the Grobman–Hartman theorem was established by Palmer [Reference Palmer24] for the case of continuous time. The discrete time version of his result (formulated in [Reference Aulbach and Wanner1]) asserts that (1.1) and (1.2) are topologically conjugated provided that the following conditions hold:
• (1.1) admits an exponential dichotomy (see [Reference Coppel12]);
• the nonlinear terms $f_n$
 are bounded and uniformly Lipschitz with a sufficiently small Lipschitz constant.

In addition, several authors obtained important extensions of the Palmer's theorem by relaxing assumptions related to the linear systems (1.1) (or its continuous counterpart). We refer to [Reference Backes and Dragičević3, Reference Backes, Dragičević and Palmer5, Reference Castañeda, González and Robledo6, Reference Castañeda and Robledo10, Reference Jiang21, Reference Lin22, Reference Reinfelds and Šteinberga27] and references therein. For recent results dealing with the higher regularity of conjugacies in nonautonomous linearization, we refer to [Reference Backes and Dragičević4, Reference Castañeda and Jara7–Reference Castañeda and Robledo9, Reference Cuong, Doan and Siegmund11, Reference Dragičević13–Reference Dragičević, Zhang and Zhang15].
An ubiquitous assumption in most of those results is the existence of a decomposition of the phase space $X$ into the stable and unstable directions along which (1.1) exhibits contraction and expansion, respectively. In other words, it is assumed that (1.1) exhibits some sort of dichotomic behaviour (although not necessarily of exponential nature). The key idea is that the lack of hyperbolicity can be compensated by properly controlling the ‘size’ of nonlinear terms $f_n$
 in (1.2). A notable exception is the work of Reinfelds and Šteinberga [Reference Reinfelds and Šteinberga27] in which the authors obtain a linearization result without any assumptions related to the asymptotic behaviour of (1.1). However, the conditions concerned with nonlinearities $f_n$
 are expressed in terms of a Green function corresponding to (1.1) which is still essentially given by decomposing $X$
 into two directions.
In this work, instead of considering a decomposition of $X$ into just two directions, we allow for a decomposition of $X$
 into several directions with possible different behaviours of (1.1) along each of those directions. Our conditions are of general form as in [Reference Backes, Dragičević and Palmer5, Reference Reinfelds and Šteinberga27] and no asymptotic behaviour is required for the linear dynamics. On the other hand, the more ‘non-hyperbolic’ the linear system is (along certain direction), the more restrictive are the assumptions on the perturbations $f_n$
 (along that direction). In fact, we allow the presence of certain directions along which we do not impose any conditions on (1.1) and on the nonlinear perturbations $f_n$
 (besides requiring those to be continuous and bounded). In this general case, we obtain only a quasi-conjugacy between systems (1.1) and (1.2), meaning that they are conjugated except for a given deviation in the directions along which we have no control. To the best of our knowledge, this is the first time such a general result appears in the literature. We stress that our results are motivated by the recent paper by Pilyugin [Reference Pilyugin25] which deals with the multiscale nonautonomous shadowing.
The paper is organized as follows. In § 2, we consider the case of discrete time, i.e. we establish sufficient conditions under which (1.1) and (1.2) are topologically conjugated. We discuss in detail the relationship between our result and related results in the literature and we provide an explicit example illustrating the strength of our result. Finally, in § 3 we establish an analogous result in the case of continuous time.
2. The case of discrete time
2.1 Preliminaries
Let $X=(X,\, | \cdot |)$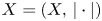 be an arbitrary Banach space and denote by $\mathcal {B}(X)$
 the space of all bounded linear operators on $X$
 . By $\|\cdot \|$
 , we will denote the operator norm on $\mathcal {B}(X)$
 . Given a sequence $(A_n)_{n\in \mathbb {N}}$
 of invertible operators in $\mathcal {B}(X)$
 and $m,\,n\in \mathbb {N}$
 , let us consider the associated linear cocycle given by

2.2 Multiscale
Let $K$ be a finite set of the form $K=K^{s} \cup K^{u}\cup K^{c}$
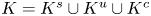 , where $K^{i}\cap K^{j}=\emptyset$
 for $i,\,j\in \{s,\,u,\,c\}$
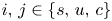 , $i\neq j$
 . Suppose that for each $n\in \mathbb {N}$
 there exists a family of projections $P^{k}_n$
 , $k\in K$
 such that

and

In particular, by considering $X_k(n)=P^{k}_n(X)$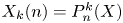 , we have that

Remark 2.1 We observe that the notion of multiscale considered in this work is more general than the one considered by Pilyugin in [Reference Pilyugin25]. Indeed, in the aforementioned work there is an extra assumption requiring that $A_nP_n^{k}=P^{k}_{n+1}A_n$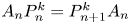 for every $n\in \mathbb {N}$
 and $k\in K$
 . Moreover, in [Reference Pilyugin25] $K$
 has the form $K=K^{s}\cup K^{u}$
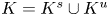 , i.e. $K^{c}=\emptyset$
 .
2.3 Standing assumptions
Given $k\in K^{s}\cup K^{u}$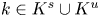 , take $\lambda _k>0$
 and let $(\mu ^{k}_n)_{n\in \mathbb {N}}$
 and $(\nu _n^{k})_{n\in \mathbb {N}}$
 be sequences of positive numbers such that:
• for $k\in K^{s}$
,
(2.2)\begin{equation} \sup_n \sum_{l=1}^{n}\|\mathcal{A}(n,l)P^{k}_l\|\nu^{k}_l<{+}\infty, \end{equation}and(2.3)\begin{equation} \sup_n \sum_{l=1}^{n}\|\mathcal{A}(n,l)P^{k}_l\|\mu^{k}_l\leq \lambda_k; \end{equation}• for $k\in K^{u}$
,
(2.4)\begin{equation} \sup_n \sum_{l=n+1}^{\infty}\|\mathcal{A}(n,l)P^{k}_l\|\nu^{k}_l<{+}\infty, \end{equation}and(2.5)\begin{equation} \sup_n \sum_{l=n+1}^{\infty}\|\mathcal{A}(n,l)P^{k}_l\|\mu^{k}_l\leq \lambda_k. \end{equation}


2.4 A linearization result
We are now ready to state our first main result.
Theorem 2.2 Let $f_n \colon X\to X$ , $n\in \mathbb {N}$
 be a sequence of maps such that $A_n+f_n$
 is a homeomorphism for each $n\in \mathbb {N}$
 and

for every $k\in K^{s}\cup K^{u}$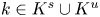 and $n\geq 1$
 , where

Moreover, assume that for each $k\in K^{s}\cup K^{u}$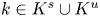 , $x,\, y\in X$
 and $n\in \mathbb {N}$
 ,

Then, if

i) there exist sequences of continuous maps $H_n:X\to X$
, $n\in \mathbb {N}$ and $\tau _n:X\to \bigoplus _{k\in K^{c}}X_k(n+1)$, $n\in \mathbb {N}$ such that
(2.9)\begin{equation} H_{n+1}\circ A_n=(A_n+f_n)\circ H_n+\tau_n\circ H_{n}, \ \text{for every }n\in \mathbb{N}. \end{equation}In addition,\[ \sup_{n\in \mathbb{N}}\lVert H_n-\text{Id} \rVert_\infty <{+}\infty \text{ and } \tau_n(x)={-}\sum_{k\in K^{c}}P^{k}_{n+1} (f_{n}(x)); \]ii) there exist sequences of continuous maps $\bar H_n:X\to X$
, $n\in \mathbb {N}$ and $\bar \tau _n:X\to \bigoplus _{k\in K^{c}}X_k(n+1)$, $n\in \mathbb {N}$ such that
(2.10)\begin{equation} \bar{H}_{n+1}\circ (A_n+f_n)=A_n \circ \bar{H}_n +\bar{\tau}_n, \ \text{for every }n\in \mathbb{N}. \end{equation}In addition,\[ \sup_{n\in \mathbb{N}}\lVert \bar H_n-\text{Id} \rVert_\infty <{+}\infty \text{ and } \bar \tau_n(x)={-}\tau_n. \]


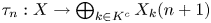


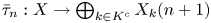


Moreover, in the case when either $K^{c}=\emptyset$ or $P^{k}_nf_{n-1}\equiv 0$
 for every $k\in K^{c}$
 and $n\geq 1$
 , we have that $H_n$
 and $\bar H_n$
 are homeomorphisms for each $n\in \mathbb {N}$
 . In addition,

and

for every $n\in \mathbb {N}$ .
Remark 2.3 We observe that in the case when we have a good control of the perturbations along all the directions (i.e., $K^{c}=\emptyset$ or $P^{k}_nf_{n-1}\equiv 0$
 for every $k\in K^{c}$
 and $n\geq 1$
 ), the previous result gives us a nonautonomous version of Grobman–Hartman's theorem. In the general case, however, we obtain a ‘quasi-conjugacy’ between systems (1.1) and (1.2), i.e. those are conjugated except for a given deviation (the factors $\tau _n$
 and $\bar \tau _n$
 in (2.9) and (2.10), respectively) in the directions along which we do not have any control.
Remark 2.4 Another important observation is the generality of theorem 2.2: we do not impose any condition on the linear maps $(A_n)_{n\in \mathbb {N}}$ but rather only on the allowed perturbations. Moreover, we allow for different levels of control on the perturbations along different directions. In particular, it generalizes previous results such as [Reference Castañeda, González and Robledo6, theorem 2.1].
Remark 2.5 We note that the classical Palmer's theorem [Reference Aulbach and Wanner1, Reference Palmer24] corresponds to the particular case when:
• $|K^{s}|=|K^{u}|=1$
and $K^{c}=\emptyset$;• there exist $D,\, \lambda >0$
such that
\[ \| \mathcal{A}(m, n)P_n\| \le De^{-\lambda (m-n)} \quad \text{for }m\ge n, \]and\[ \| \mathcal{A}(m,n)\tilde P_n\| \le De^{-\lambda (n-m)} \quad \text{for }m\le n, \]where $P_n=P_n^{a}$ and $\tilde P_n=P_n^{b}$ for $n\in \mathbb {N}$, $K^{s}=\{a\}$, $K^{u}=\{b\}$.
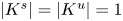


It is easy to verify that in this setting theorem 2.2 is applicable whenever $(\nu _l^{k})$ and $(\mu _l^{k})$
 are constant sequences, and $\mu _l^{k}$
 is sufficiently small.
Remark 2.6 Let $K^{s}$ and $K^{u}$
 satisfy the same properties as in remark 2.5. We emphasize that in the case when $|K^{c}|=1$
 , a result similar to theorem 2.2 was established (by using different techniques and under some additional assumptions) in [Reference Backes and Dragičević2, Theorem 3].
As an illustration of the broad applicability of Theorem 2.2 we provide the following simple example.
Example 2.7 Take $X=\mathbb {R}^{5}$ and $K=\{1,\,2,\,3,\,4,\,5\}$
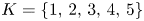 . For each $k\in K$
 and $n\in \mathbb {N}$
 , let $P^{k}_n$
 be the projection onto the $k^{th}$
 coordinate. Moreover, let $(A_n)_{n\in \mathbb {N}}$
 be a sequence of constant diagonal matrices given by

and consider $K^{s}=\{1,\,2\}$ , $K^{c}=\{3\}$
 and $K^{u}=\{4,\,5\}$
 . Take $\lambda _k=\frac {1}{5}$
 for every $k\in K$
 and
• $\nu ^{k}_n=1$
and $\mu ^{k}_n=\frac {1}{10}$, for $k\in \{1,\,5\}$ and $n\in \mathbb {N}$;• $\nu ^{k}_n=\frac {1}{2^{n}}$
and $\mu ^{k}_n=\frac {1}{5\cdot 2^{n}}$, for $k\in \{2,\,4\}$ and $n\in \mathbb {N}$.


Let $f_n\colon X\to X$ , $f_n=(f_n^{1},\, \ldots,\, f_n^{5})$
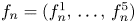 , $n\in \mathbb {N}$
 be a sequence of continuous maps such that
• $\|f_{n-1}^{k}\|_\infty \le 1$
and $Lip(f_{n-1}^{k})\le \frac {1}{10}$, for $k\in \{1,\,5\}$ and $n\ge 1$;• $\|f_{n-1}^{k}\|_\infty \le \frac {1}{2^{n}}$
and $Lip(f_{n-1}^{k})\le \frac {1}{5\cdot 2^{n}}$, for $k\in \{2,\, 4\}$ and $n\ge 1$.
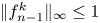
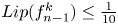


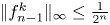
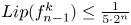


It is easy to verify that under the above assumptions, theorem 2.2 is applicable. Observe the different levels of control we allow along each direction: the more ‘hyperbolic’ a direction is, the less restrictive are the conditions on the perturbations along such a direction.
2.5 Proof of theorem 2.2
In this subsection we present the proof of theorem 2.2. For the sake of clarity, we will divide it into several steps.
Let $\mathcal {Y}$ denote the space of all sequences $\mathbf {h}=(h_n)_{n\in \mathbb {N}}$
 of continuous maps $h_n:X\to X$
 such that

It is easy to verify that $(\mathcal {Y},\, \lVert \cdot \rVert _{\mathcal {Y}})$ is a Banach space.
Construction of maps $H_n$:

Let us consider the operator $\mathcal {T}\colon \mathcal {Y} \to \mathcal {Y}$ given by

where
• for $k\in K^{s}$
, we set $(\mathcal {T}_k\mathbf {h})_0 (x)=0$ and
\[ (\mathcal{T}_k\mathbf{h})_n (x) = \sum_{l=1}^{n} \mathcal{A}(n, l)P^{k}_l (f_{l-1}(\mathcal{A}(l-1, n)x+h_{l-1}(\mathcal{A}(l-1, n)x))), \]for $n\geq 1$;• for $k\in K^{u}$
, we define
\[ (\mathcal{T}_k\mathbf{h})_n (x) ={-}\sum_{l=n+1}^{\infty} \mathcal{A}(n, l)P^{k}_l(f_{l-1}(\mathcal{A}(l-1, n)x+h_{l-1}(\mathcal{A}(l-1, n)x))), \]for every $n\in \mathbb {N}$ and $x\in X$.

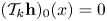


Since $P^{k}_l=P_l^{k} P^{k}_l$ , we have that

which combined with (2.2), (2.4) and (2.6) implies that

Moreover, one can easily see that for every $\mathbf {h}\in \mathcal {Y}$ and $n\in \mathbb {N}$
 , $(\mathcal {T}\mathbf {h})_n$
 is continuous. Hence, $\mathcal {T}\colon \mathcal {Y} \to \mathcal {Y}$
 is well-defined. We now claim that $\mathcal {T}\colon \mathcal {Y} \to \mathcal {Y}$
 is a contraction. Indeed, take $\mathbf {h}^{i}=(h_n^{i})_{n\in \mathbb {Z}} \in \mathcal {Y}$
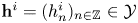 , $i=1,\, 2$
 . Using (2.3) and (2.7) we get that for each $k\in K^{s}$
 ,

for $x\in X$ and $n\in \mathbb {N}$
 . Similarly, for each $k\in K^{u}$
 ,

for $x\in X$ and $n\in \mathbb {N}$
 . Consequently,

for every $x\in X$ and $n\in \mathbb {N}$
 and thus,

Hence, by (2.8) we conclude that $\mathcal {T}$ is a contraction. Therefore, $\mathcal {T}$
 has a unique fixed point $\mathbf {h}=(h_n)_{n\in \mathbb {N}}\in \mathcal {Y}$
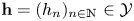 . Thus, we have that

for $x\in X$ and $n\in \mathbb {N}$
 . Now, for $k\in K^{s}$
 , $x\in X$
 and $n\geq 1$
 , we have that

Similarly, for $k\in K^{s}$ , $x\in X$
 and $n=0$
 , we observe that

Finally, for $k\in K^{u}$ , $x\in X$
 and $n\in \mathbb {N}$
 , we have that

Combining these observations with (2.1), (2.13) and the fact that $\mathbf {h}$ is a fixed point of $\mathcal {T}$
 , we obtain that

for $n\in \mathbb {N}$ and $x\in X$
 . Consequently, defining $H_n=\text {Id}+h_n$
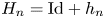 , $n\in \mathbb {N}$
 , and $\tau _n:X\to \bigoplus _{k\in K^{c}}X_k(n+1)$
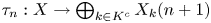 by $\tau _n(x)=-\sum _{k\in K^{c}}P^{k}_{n+1} (f_{n}(x))$
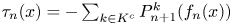 for $n\in \mathbb {N}$
 , we get that (2.9) holds.
Construction of maps $\bar {H}_n$:

We now consider $\mathbf {\bar h}=(\bar h_n)_{n\in \mathbb {N}} \in \mathcal {Y}$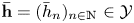 given by

where
• for $k\in K^{s}$
, we set $\bar h^{k}_0 (x)=0$ and
\[ \bar h^{k}_n (x)={-}\sum_{l=1}^{n} \mathcal{A}(n, l)P^{k}_lf_{l-1}(\mathcal{F}(l-1, n)x) \quad \text{for }n\ge 1, \]where\[ \mathcal{F}(m, n)=\begin{cases} F_{m-1}\circ \ldots F_n & \text{for }m>n;\\ \text{ Id} & \text{for }m=n;\\ F_{m+1}^{{-}1}\circ \ldots \circ F_n^{{-}1} & \text{for }m< n, \end{cases} \]and $F_n=A_n+f_n$, $n\in \mathbb {N}$;• for $k\in K^{u}$
and $n\in \mathbb {N}$,
\[ \bar h^{k}_n (x)= \sum_{l=n+1}^{\infty} \mathcal{A}(n, l)P^{k}_lf_{l-1}(\mathcal{F}(l-1, n)x). \]


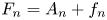


It follows easily from (2.2), (2.4) and (2.6) that indeed $\mathbf {\bar h}\in \mathcal {Y}$ . Moreover, we observe that given $x\in X$
 and $k\in K^{s}$
 , we have that

for $n\geq 1$ . Similarly, for $x\in X$
 and $n=0$
 , we observe that

Moreover, for $k\in K^{u}$ , $x\in X$
 and $n\in \mathbb {N}$
 , we have that

Consequently, using (2.1) and recalling the definition of $\bar {\mathbf {h}}$ , it follows that for every $n\in \mathbb {N}$
 and $x\in X$
 ,

Thus, defining $\bar {H}_n=\text {Id}+\bar {h} _n$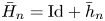 , $n\in \mathbb {N}$
 , and $\bar \tau _n:X\to \bigoplus _{k\in K^{c}}X_k(n+1)$
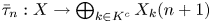 by $\bar \tau _n(x)=\sum _{k\in K^{c}}P^{k}_{n+1} (f_{n}(x))$
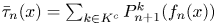 for $n\in \mathbb {N}$
 , we conclude that (2.10) holds.
The cases when $K^{c}=\emptyset$ and $P_n^{k}f_{n-1}\equiv 0$ for every $k\in K^{c}$:


Suppose that either $K^{c}=\emptyset$ or $P_n^{k}f_{n-1}\equiv 0$
 for every $k\in K^{c}$
 and $n\in \mathbb {N}$
 . Hence, we have that $\tau _n=\overline {\tau }_n=0$
 for every $n\in \mathbb {N}$
 . In particular, (2.9) and (2.10) imply that

for every $n\in \mathbb {N}$ . Hence, (2.12) holds. Moreover, it follows easily from (2.14) that

and

for every $m,\,n\in \mathbb {N}$ .
Recalling the definitions of $\bar H_n$ and $H_n$
 we get that for every $n\geq 1$
 and $x\in X$
 ,

Now, by (2.15) it follows that

which combined with (2.17) implies that $\bar H_n(H_{n}(x))=x$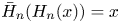 for every $x\in X$
 . The case when $n=0$
 can be treated similarly.
Our objective now is to show that $H_n(\bar H_{n}(x))=x$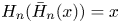 for every $x\in X$
 and $n\in \mathbb {N}$
 . We start by observing that

Consequently,

By analysing the right-hand side of (2.18), we have that

for $x\in X$ and $n\ge 1$
 . On the other hand, by using (2.16) we have that

Thus, combining the previous observations we get that

Therefore, using (2.18) it follows that

Now, since $\textbf {h}=(h_n)_{n\in \mathbb {N}}\in \mathcal {Y}$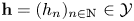 and $\bar {\textbf {h}}=(\bar {h}_n)_{n\in \mathbb {N}}\in \mathcal {Y}$
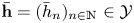 , it follows by (2.18) that $\textbf {H}\circ \bar {\textbf {H}}-\text {Id}:=(H_n\circ \bar {H}_n-\text {Id})_{n\in \mathbb {N}}\in \mathcal {Y}$
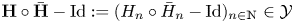 , which combined with (2.3), (2.5) and (2.19) implies that

Thus, from (2.8) it follows that $\|\textbf {H}\circ \bar {\textbf {H}}-\text {Id}\|_{\mathcal {Y}}=0$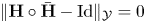 , and consequently $H_n(\bar H_{n}(x))=x$
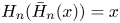 for every $x\in X$
 and $n\in \mathbb {N}$
 .
Summarizing, we have proved that (2.11) holds. In particular, we conclude that $H_n$ and $\bar H_n$
 are homeomorphisms for each $n\in \mathbb {N}$
 . The proof of theorem 2.2 is completed.
3. The case of continuous time
The purpose of this section is to establish the version of theorem 2.2 for the case of continuous time. Let $A\colon [0,\, \infty )\to \mathcal {B}(X)$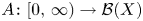 and $f\colon [0,\, \infty )\times X\to X$
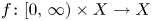 be continuous maps. We consider the associated semilinear differential equation

as well as the associated linear equation

By $T(t,\,s)$ we will denote the evolution family associated to (3.2). Furthermore, $U(t,\,s)$
 will denote the nonlinear evolution family corresponding to (3.1), i.e. $U(t,\,s)v=x(t)$
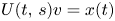 , where $x\colon [0,\, \infty )\to X$
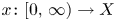 is the solution of (3.1) such that $x(s)=v$
 .
Let $K$ be as in subsection 2.2. Suppose that for each $t\ge 0$
 and $k\in K$
 there is a projection $P^{k}(t)$
 on $X$
 such that:
• $\sum _{k\in K} P^{k}(t)=\text {Id}$
;• $P^{k}(t)P^{l}(t)=0$
for $k,\, l\in K$, $k\neq l$;• for $k\in K$
, $t\mapsto P^{k}(t)$ is measurable.
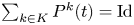
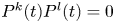


Furthermore, we assume that there are Borel measurable functions $\mu ^{k},\, \nu ^{k} \colon [0,\, \infty )\to [0,\, \infty )$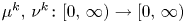 and positive numbers $\lambda _k>0$
 , $k\in K^{s} \cup K^{u}$
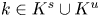 such that:
• for $k\in K^{s}$
,
(3.3)\begin{equation} \sup_t \int_0^{t}\|T(t,s)P^{k}(s)\|\nu^{k}(s)\, ds<{+}\infty, \end{equation}and(3.4)\begin{equation} \sup_t \int_0^{t}\|T(t,s)P^{k}(s)\|\mu^{k}(s)\, ds\le \lambda_k; \end{equation}• for $k\in K^{u}$
,
(3.5)\begin{equation} \sup_t \int_t^{\infty} \|T(t,s)P^{k}(s)\|\nu^{k}(s)\, ds<{+}\infty, \end{equation}and(3.6)\begin{equation} \sup_t \int_t^{\infty} \|T(t,s)P^{k}(s)\|\mu^{k}(s)\, ds\le \lambda_k. \end{equation}


The following is the version of theorem 2.2 in the present setting.
Theorem 3.1 Assume that the following conditions hold:
• for $k\in K^{s}\cup K^{u}$
and $t\ge 0,$
(3.7)\begin{equation} \|P^{k}(t)f(t, \cdot)\|_\infty \le \nu^{k}(t); \end{equation}• for $k\in K^{s}\cup K^{u},$
$t\ge 0$ and $x,\, y\in X,$
(3.8)\begin{equation} |P^{k}(t)f(t, x)-P^{k}(t)f(t, y)| \le \mu^{k}(t)|x-y|; \end{equation}• (2.8) holds.
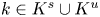


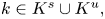


Then,
• there exists a continuous map $H\colon [0,\, \infty )\times X\to X$
such that if $t\mapsto x(t)$ is a solution of (3.2) , then $t\mapsto H(t,\, x(t))$ is a solution of
(3.9)\begin{equation} x'=A(t)x+\sum_{k\in K^{s}\cup K^{u}} P^{k}(t)f(t,x); \end{equation}• there exists a continuous map $\bar H\colon [0,\, \infty )\times X\to X$
such that if $t\mapsto y(t)$ is a solution of (3.1) , then $t\mapsto \bar H(t,\, y(t))$ is a solution of
(3.10)\begin{equation} x'=A(t)x+\sum_{k\in K^{c}} P^{k}(t)f(t,y(t))); \end{equation}• we have that
(3.11)\begin{equation} \sup_{t} \|H(t, \cdot)-\text{Id} \|_\infty<{+}\infty \quad \text{and} \quad \sup_{t} \|\bar H(t, \cdot)-\text{Id}\|_\infty<{+}\infty. \end{equation}
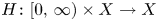

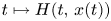

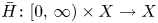

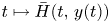


Moreover, in the case when $K^{c}=\emptyset$ or $P^{k}(t)f(t,\, \cdot )\equiv 0$
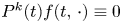 for $t\ge 0$
 and $k\in K^{c},$
 then $H(t,\, \cdot )$
 and $\bar H(t,\, \cdot )$
 are homeomorphisms for each $t\ge 0$
 satisfying


for $t,\, s\ge 0$ and $x\in X$
 .
Proof. We follow closely the proof of theorem 2.2. Let $\mathcal {Y}$ denote the space of all continuous functions $h\colon [0,\, \infty )\times X\to X$
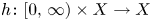 such that

Then, $(\mathcal {Y},\, \| \cdot \|_{\mathcal {Y}})$ is a Banach space. We define an operator $\mathcal {T}\colon \mathcal {Y}\to \mathcal {Y}$
 by

where
• for $k\in K^{s}$
, we set
\[ (\mathcal{T}_kh) (t, x) = \int_0^{t} T(t, s)P^{k}(s) (f(s, T(s, t)x+h(s, T(s, t)x)))\, ds, \]for every $t\ge 0$ and $x\in X$;• for $k\in K^{u}$
, we set
\[ (\mathcal{T}_k h)(t, x) ={-}\int_{t}^{\infty} T(t, s)P^{k}(s)(f(s, T(s, t)x+h(s, T(s, t)x)))\, ds, \]for every $t\ge 0$ and $x\in X$.


Observe that

which combined with (3.3), (3.5) and (3.7) implies that

This easily implies that $\mathcal {T}h\in \mathcal {Y}$ . Take now $h^{1},\, h^{2}\in \mathcal {Y}$
 . By using (3.4) and (3.8) we get that for each $k\in K^{s}$
 ,

for $x\in X$ and $t\ge 0$
 . Similarly, by using (3.6) and (3.8), we have that for each $k\in K^{u}$
 ,

for $x\in X$ and $t\ge 0$
 . Consequently,

for every $x\in X$ and $t\ge 0$
 and thus,

Hence, by (2.8) we conclude that $\mathcal {T}$ is a contraction. Therefore, $\mathcal {T}$
 has a unique fixed point $h\in \mathcal {Y}$
 . Therefore,

for $x\in X$ and $t,\, s\ge 0$
 . Now, for $k\in K^{s}$
 , $x\in X$
 and $t,\, s\ge 0$
 , we have that

Similarly, for $k\in K^{u}$ , $x\in X$
 and $t,\, s\ge 0$
 , we have that

Combining these observations with (3.14) and the fact that $h$ is a fixed point of $\mathcal {T}$
 , we obtain that

for $t,\, s\ge 0$ and $x\in X$
 . By differentiating the above equality, we easily conclude that if $t\mapsto x(t)$
 is a solution of (3.2), then $t\mapsto H(t,\, x(t))$
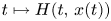 is a solution of (3.9), where $H(t,\,x):=x+h(t,\,x)$
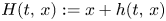 .
We now consider $\bar h \in \mathcal {Y}$ given by

where
• for $k\in K^{s}$
and $t\geq 0$,
\[ \bar h^{k} (t, x):={-}\int_{0}^{t} T(t, s)P^{k}(s) f(s, U(s, t)x)\, ds; \]• for $k\in K^{u}$
and $t\ge 0$,
\[ \bar h^{k} (t, x):= \int_{t}^{\infty} T(t, s)P^{k}(s) f(s, U(s,t)x)\, ds. \]


It follows easily from (3.3), (3.5) and (3.7) that indeed $\bar h\in \mathcal {Y}$ . Moreover, we observe that given $x\in X$
 and $k\in K^{s}$
 , we have that

for $t,\, s\ge 0$ and $x\in X$
 . Moreover, for $k\in K^{u}$
 , $x\in X$
 and $t,\, s \ge 0$
 , we have that

Consequently, it follows that for $t,\, s\ge 0$ we have that

From this we easily conclude that if $t\mapsto y(t)$ is a solution of (3.1), then $t\mapsto \bar H(t,\, y(t))$
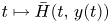 is a solution of (3.10), where $\bar H(t,\,x)=x+\bar h(t,\,x)$
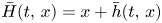 . Finally, we observe that since $h,\, \bar h\in \mathcal {Y}$
 , we have that (3.11) holds.
Suppose now that either $K^{c}=\emptyset$ or $P^{k}(t)f(t,\, \cdot )\equiv 0$
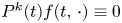 for every $k\in K^{c}$
 and $t\in \mathbb {R}$
 . From the previous observations, we conclude that (3.13) holds for $t,\, s\ge 0$
 and $x\in X$
 . Moreover, for every $t\ge 0$
 and $x\in X$
 , we have that

By applying (3.13), we conclude that $\bar H(t,\, H(t,\, x))=x$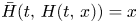 for $x\in X$
 and $t\ge 0$
 .
We now claim that $H(t,\,\bar H(t,\, x))=x$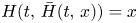 for $x\in X$
 and $t\ge 0$
 . Observe that

For $t\ge 0$ , we have that

By (3.13), we have that

and thus

Therefore, using (3.15) it follows that

Set

Now, since $h,\, \bar h\in \mathcal {Y}$ , it follows from (3.15) that $G \in \mathcal {Y}$
 , which combined with (3.4) and (3.6) implies that

Thus, from (2.8) it follows that $G=0$ , and consequently $H(t,\, \bar H(t,\, x))=x$
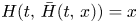 for every $x\in X$
 and $t\ge 0$
 . We conclude that (3.12) holds which completes the proof of the theorem.
Example 3.2 Let $X$ and $K$
 be as in example 2.7. For $t\ge 0$
 and $k\in K$
 , let $P^{k}(t)$
 be the projection onto the $k^{th}$
 coordinate. Moreover, take

and consider $K^{s}=\{1,\,2\}$ , $K^{c}=\{3\}$
 and $K^{u}=\{4,\,5\}$
 . Take $\lambda _k=\frac {1}{5}$
 for every $k\in K$
 and
• $\nu ^{k}(t)=1$
and $\mu ^{k}(t)=\frac {1}{5}$, for $k\in \{1,\,5\}$ and $t\ge 0$;• $\nu ^{k}(t)=e^{-t}$
and $\mu ^{k}_n=\frac {1}{5}e^{-t}$, for $k\in \{2,\,4\}$ and $t\ge 0$.


Let $f\colon [0,\, \infty )\times X\to X$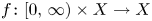 , $f=(f^{1},\, \ldots,\, f^{5})$
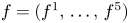 be a continuous map such that
• $\|f^{k}(t,\, \cdot )\|_\infty \le 1$
and $Lip(f^{k}(t,\, \cdot ))\le \frac {1}{5}$, for $k\in \{1,\,5\}$ and $t\ge 0$;• $\|f^{k}(t,\, \cdot )\|_\infty \le e^{-t}$
and $Lip(f^{k}(t,\, \cdot ))\le \frac {1}{5}e^{-t}$, for $k\in \{2,\, 4\}$ and $t\ge 0$.
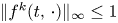
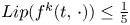


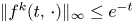
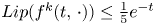


It is easy to verify that under the above assumptions, theorem 3.1 is applicable.
Acknowledgments
L.B. was partially supported by a CNPq-Brazil PQ fellowship under Grants No. 306484/2018-8 and 307633/2021-7. D.D. was supported in part by Croatian Science Foundation under the project IP-2019-04-1239 and by the University of Rijeka under the projects uniri-prirod-18-9 and uniri-prprirod-19-16.



