1. Introduction
The concept of PMs emerged in the late 19th century and has seen significant development in recent years due to its superior load-bearing capacity, high-speed motion, and precision. The 3T PM, a type of PM, finds applications in diverse fields, including industrial manufacturing, logistics, transportation, and healthcare. In the early 20th century, Ciavel et al. designed the 3T Delta mechanism, particularly the 3T redundant-actuated Delta/Par4-like manipulator with CLU [Reference Corbel, Gouttefarde, Company and Pierrot1]. This design has become widely used in logistics sorting, industrial packaging, and product placement, owing to its excellent dynamic performance and high load capacity. This is mainly due to the advantages of compactness, cost-effectiveness, and simpler control offered by PMs with CLU compared to conventional PMs. Additionally, CLU plays a crucial role in enhancing the mechanism’s reliability [Reference Zhao, Guo and Qu2–Reference Wang, Xiong, Zhang and Yuan4]. Consequently, incorporating the CLU into the branch chain of PMs has become an effective approach in type synthesis. However, compared to traditional 3T PMs, the configuration options for the 3T redundant-actuated PMs with CLU are limited, and most existing CLU configurations rely on a relatively simple quadrilateral structure. Therefore, many scholars have conducted in-depth research in this area [Reference Meng, Xie and Liu5–Reference Song, Yang, Zhang, Fang and Zou16].
The redundantly actuated PM, with more actuators than the output DOF of the moving platform, can effectively reduce singularities by adding redundant actuated joints, expand the reachable workspace, and improve the fault tolerance, among other advantages [Reference Wang, Fang, Guo and Zhou17–Reference Jiang, Huang, Zhu, Fang, Tian, Xie, Zhang, Zhao, Gu and Kong23]. Adding extra actuated joints to the redundant actuated PM enhances its load-carrying capacity and improves its dynamics, even under the same structural stiffness. Kim et al. designed a redundantly actuated 3-PPRS parallel machine tool, where redundant actuation not only eliminated certain singular configurations in the workspace but also improved the system’s overall stiffness [Reference Jongwon, Jae-Chul, Jin-Sung and Park24]. Xie et al. designed a novel 4-DOF parallel machine tool containing a CLU based on the atlas method, optimizing the design to achieve high rotational potential through kinematic and force-transfer performance indices [Reference Xie and Liu25]. Xu et al. proposed a new method for solving the reaction forces in a redundantly actuated PM and investigated the control strategy for coordinated motion forces [Reference Xu, Yao and Zhao26]. Li et al. analyzed the internal singularities of a 3T PM and proposed a synthesis method for eliminating these singularities by using the linear correlation and independence of helixes in the redundant branched chain [Reference Li, Cui and Liu27]. Zhao et al. proposed a 3-5RS redundant-actuated PM containing CLU and analyzed its static stiffness using the Jacobi matrix, which confirmed a significant improvement in stiffness compared to the 3-RPS PM with open-loop branched chains [Reference Zhao, Guo and Qu2]. Guo et al. proposed a systematic approach for triple-translational redundantly actuated PMs by selecting a single-ring or multi-ring mechanism as the branched-chain driving unit and coupling the possible constraints within the branched-chain unit, resulting in a 3T redundantly actuated PM with non-overconstraints and low-order overconstraints [Reference Guo28]. Ye et al. designed a hybrid branched chain with reconfigurable characteristics containing a CLU and synthesized a new class of reconfigurable PMs by rationally configuring the hybrid branched chain [Reference Ye, Fang, Guo and Wen29]. Zhao et al. proposed a PM with CLU, developed a kinematic model in generalized coordinates, and verified it through numerical simulation [Reference Zhao, Zhao, Wang, Tian and Chen30]. Shen et al. proposed a novel 3-DOF PM containing CLU, which eliminates parasitic motion, and analyzed the positive and negative solutions using a kinematic modeling method based on topological properties [Reference Shen, Tang, Ceccarelli, Li, Li and He31]. Liu et al. proposed a novel symmetric 6-RPS PM with multiple redundant actuations, established transfer performance indices, and analyzed the mechanism’s workspace and performance distributions using optimal dimensions [Reference Liu, Wan, Liu, Chen, Yao and Zhao7].
In a recent work [Reference Li, Zhang and Zhang6], we constructed redundantly actuated branched chains with CLU by adding redundant lines to the constraint line diagrams based on the atlas method, which was used to synthesize a class of 2R1T and 2T1R redundantly actuated PMs. However, we found that when synthesizing the 3T redundantly actuated PM, particularly when it contains CLU, adding linearly correlated redundant lines to the constraint line diagrams becomes ineffective, because the constraint couple quantities are free vectors independent of position. This results in the failure of the CLU construction. Therefore, in this paper, we extend the DOF line diagrams of redundantly actuated branched chains containing CLU by combining the principle of line equivalence and further complete the type synthesis method for synthesizing redundantly actuated PMs containing CLU based on the atlas method.
In summary, existing configurations are primarily designed for specific applications, with relatively few 3T redundantly actuated PMs containing CLU, and even fewer configurations featuring CLU. Moreover, a systematic and applicable type synthesis method for 3T redundantly actuated PMs containing CLU has yet to be proposed. The main contributions of this work are summarized as follows:
-
1. A type synthesis method for 3T redundant actuated PMs with CLU, based on the atlas method, is introduced.
-
2. A variety of novel branched chains containing CLU are synthesized.
-
3. Two assembly schemes for 3T redundant actuated PMs with CLU are proposed, synthesizing at least 432 and 324 novel configurations, respectively.
The paper is organized as follows: Section 2 outlines the basic guidelines for using the atlas method. Section 3 introduces the synthesis method for 3T redundant actuated PMs with CLU. Section 4 details the synthesis process of the 3T redundant actuated PM with CLU. Section 5 verifies the DOF of the synthesized mechanism based on screw theory. Finally, Sections 6 and 7 provide the discussion and conclusions, respectively.
2. Elementary theory
2.1 Atlas method
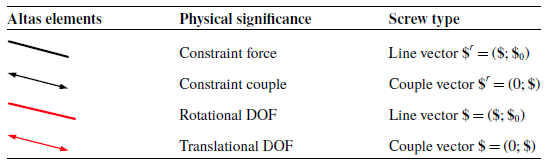
The atlas method transforms the abstract spiral theory into a visual representation and a concrete line diagram, applicable to the design of both rigid and complex flexible mechanisms [Reference Meng, Xie, Tang and Liu32–Reference Zhang, Huang, Mei and Li35]. It offers a simple, practical approach for subsequent mechanism design, with broad application prospects. The atlas method involves four graph elements, as shown in Table I: black line, black line with arrows at both ends, red line, and red line with arrows at both ends. These represent the constraint force, constraint couple, rotational DOF, and translational DOF, respectively. The plain line corresponds to the screw theory line vector, while the line with arrows represents the screw theory dual vector. $ r and $ represent the constraints and kinematic screw, respectively.
Elemental representation of the atlas.

2.2 Blanding rule
Blanding’s rule, also known as the dual rule, states that if a graph contains n non-redundant lines, its dual will contain 6-n non-redundant lines. Furthermore, each line in the graph will intersect all lines in the dual’s line graph. Applying Blanding’s rule enables the derivation of a unique DOF line graph from a constraint line graph, or vice versa. When combined with the atlas method, this facilitates the transformation between constraint line graphs and DOF line graphs [Reference Zhang, Kang and Li36]. The generalized Blanding’s rule applied in this article includes the following:
-
(1) The sum of the dimensions of a DOF line and its corresponding constraint line is equal to 6.
-
(2) The line vectors in a line graph are coplanar (either intersecting or parallel) with those in the corresponding line graph and are perpendicular to the evens in that graph. Specifically, the axes of revolute pairs intersect with or run parallel to the force axes and are perpendicular to the directions of couple constraints; conversely, the force axes intersect with or are parallel to the revolute pair axes and are perpendicular to the directions of prismatic pairs.
-
(3) The evens in a line graph are perpendicular to the line vectors in the corresponding line graph and may be arranged arbitrarily with respect to the evens in that graph. Specifically, the directions of prismatic pairs are perpendicular to the force axes and can be arranged arbitrarily relative to the directions of couple constraints, while the directions of couple constraints are perpendicular to the revolute pair axes and may be arranged arbitrarily relative to the prismatic pair directions.
2.3 The principle of line equivalence
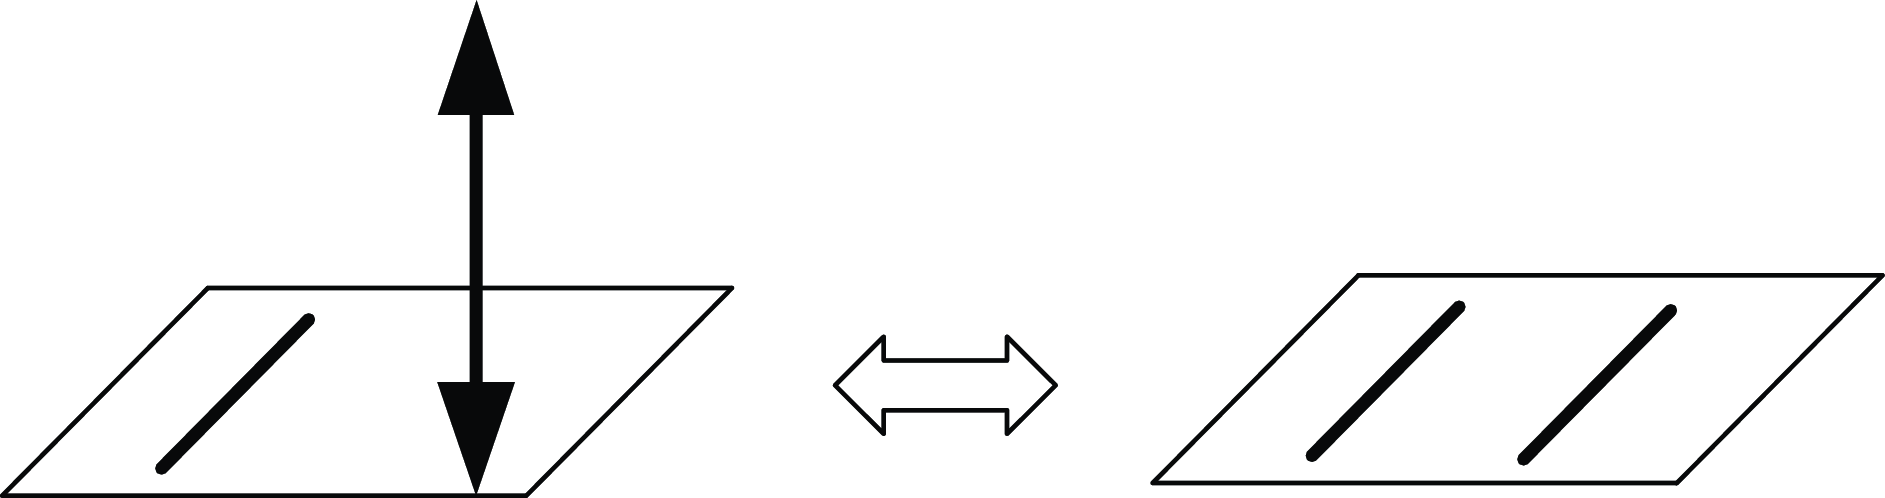
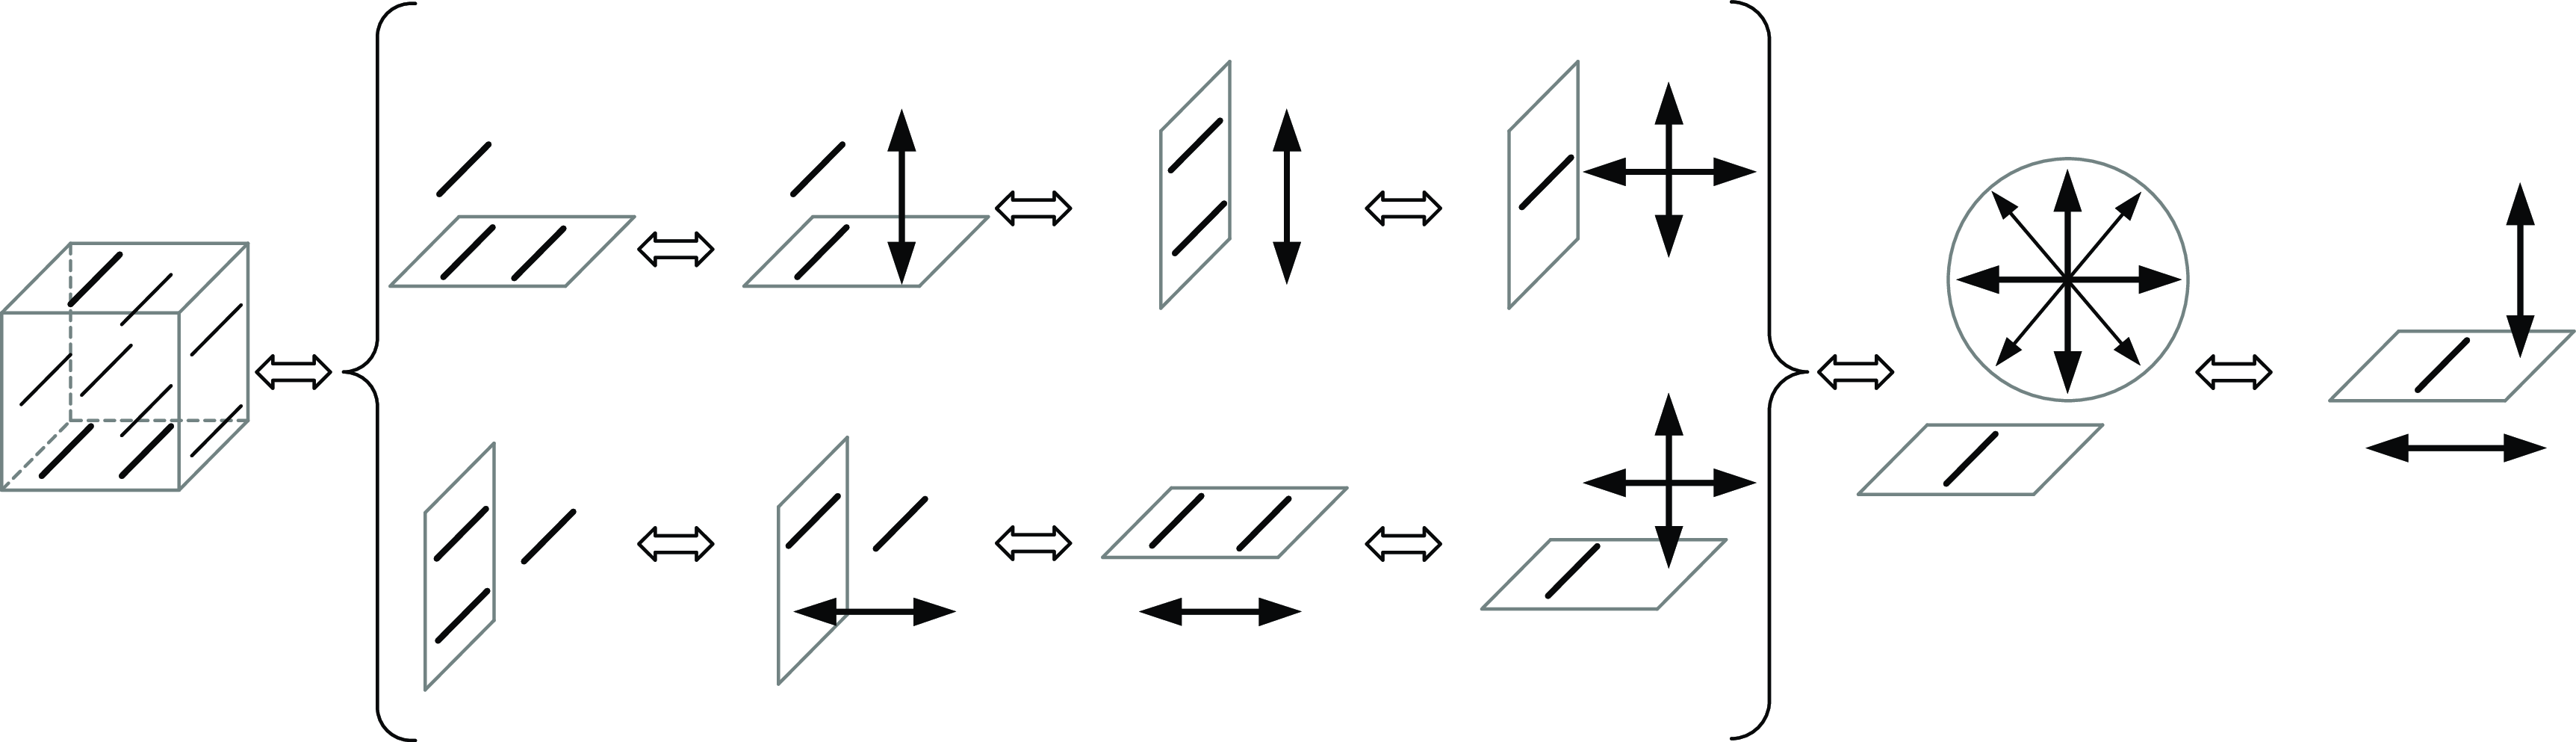
The principle of planar parallel line equivalence states that if a DOF or constraint line pattern contains a single dual vector and a line perpendicular to it, the pattern is equivalent to one with planar parallel lines (see Figure 1). As shown in Figure 2, the equivalence of plane parallel lines is extended to three-dimensional space, resulting in the equivalence of spatial parallel lines [Reference Zhang, Huang, Mei and Li35].
Planar parallel lines equivalence.

The derivation process of the principle of spatial parallel line equivalence.

3. A method for synthesizing three-translation redundant actuated parallel mechanisms with closed-loop units
This section introduces a type synthesis method for 3T redundant actuated PMs with CLU, based on the atlas method. The steps are as follows:
-
1. Determine the DOF and motion properties of the moving platform based on the movement requirements.
-
2. Plot the DOF space of the moving platform.
-
3. According to the dual rule, draw the constraint space that is dual to the space of DOF.
-
4. Decompose the constraint space to identify multiple subspaces.
-
5. Determine the form, number, and constraint properties of the branched chain arrangement. To improve stability, the arrangement of branch chains should exhibit geometric symmetry. The greater the symmetry of the mechanism, the better its overall performance [Reference Zhang, Huang, Mei and Li35].
-
6. Select the branch chain constraint line patterns based on their constraint properties.
-
7. Plot the branch chain DOF spaces using the Blanding rule.
-
8. Decompose the DOF space based on the branch chain structure characteristics.
-
9. Expand the line pattern using the principle of line equivalence. The rotational DOF line graph can be equivalent to the translational DOF line graph, and vice versa.
-
10. Create the CLU branch chain based on the DOF line graph. In this step, the instantaneous configurations of the branch chains should be considered. The directions of the kinematic pairs in some branch chains change during movement, which may affect their constraints and alter their DOF properties. These properties are determined by the branch chain structure. When constructing the branch chain, if a prismatic joint is present, it should be installed on the fixed platform. Alternatively, if the branch chain contains two prismatic joints, they can be fixed to both the moving and fixed platforms. If the prismatic joint cannot be fixed, its direction change should be considered during branch chain movement, especially when the joint moves perpendicularly to its initial position. Similarly, the direction change of partial revolute joints will also vary during movement and should be accounted for during construction.
The branch chain construction follows these primary principles: (a) When the branch chain contains a prismatic joint, it can be fixed to a fixed platform to maintain a constant direction of movement. (b) When the branch chain contains two prismatic joints, these can be fixed to the fixed and moving platforms, respectively. (c) If the prismatic joint cannot be fixed to either the fixed or moving platform, the change in the nature of the DOF due to its orientation change must be considered. (d) If the direction of a rotating joint becomes perpendicular to its initial position during branching motion, it is necessary to consider whether the branching constraint direction will change, to avoid altering the DOF nature of the moving platform. After constructing the branched chain, verify that its DOF and constraint line graphs adhere to Blanding’s rule.
-
11. Select the CLU based on the constraint requirements and structural feasibility.
-
12. Assemble each CLU into PMs based on the requirements.
-
13. Apply screw theory to verify the DOF properties of the new mechanism.
-
14. Verify the continuity of the PM.
-
15. Select the driving pair; typically, either the prismatic or revolute joint connected to the frame can serve as the driving pair.
-
16. Configuration complete.
The process diagram of the method presented above is shown in Figure 3.
Synthesis process diagram of the 3T redundantly actuated PM containing CLU.

DOF space of 3T PM.

Constraint space of 3T PM.

4. Type synthesis of three-translation redundant actuated parallel mechanisms with closed-loop units
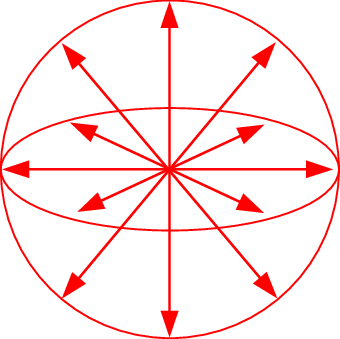
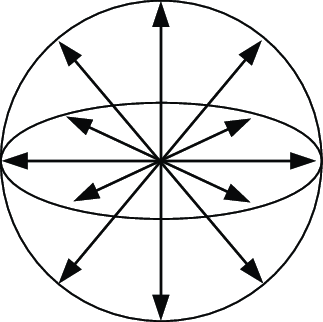
The DOF space of the 3T PM consists of three translational DOF, represented by a line graph according to the atlas method, as shown in Figure 4.
The constraint space is illustrated in Figure 5.
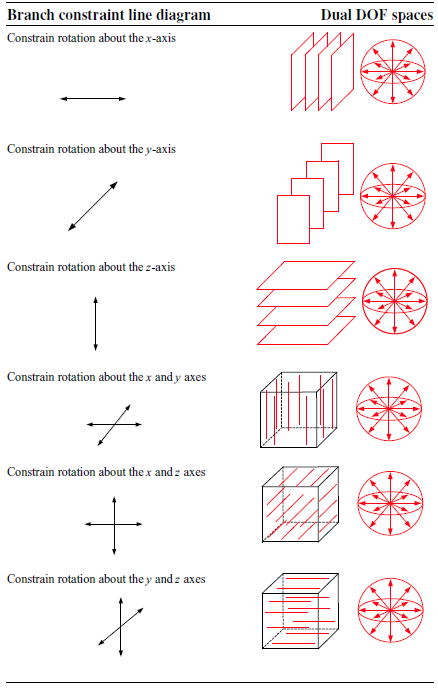
The constraint line space is decomposed, and the resulting constraint line graph and the dual’s DOF space are shown in Table II.
When the distribution of the branched chains in the PM exhibits geometric symmetry, the mechanism demonstrates improved stiffness and motion properties, which benefits subsequent kinematic, dynamic, workspace, and other analyses. In this synthesis method, four branched chains are used and arranged symmetrically [Reference Li, Zhang and Zhang6].
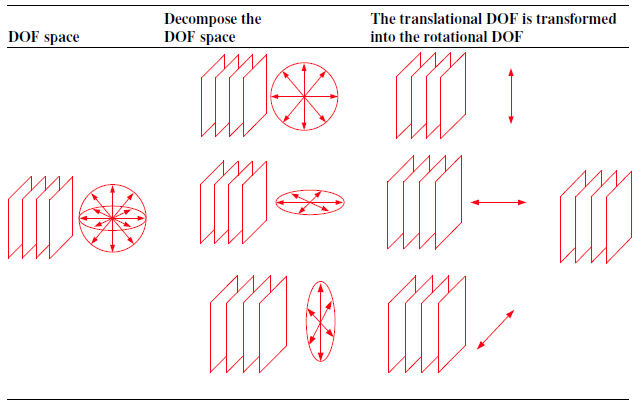
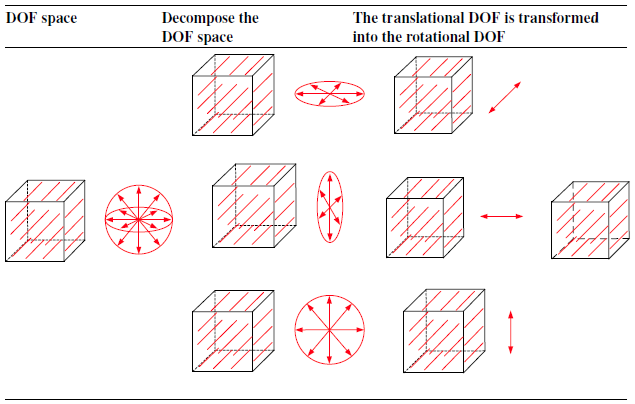
For the DOF space constrained by the x-axis rotation in the branched chain, the DOF space can be decomposed. According to the line equivalence principle, the translational DOF is transformed into rotational DOF, allowing the branched chain design to be conducted based on both translational and rotational DOFs (see Table III).
Decomposed constraint line graphs and dual DOF spaces.

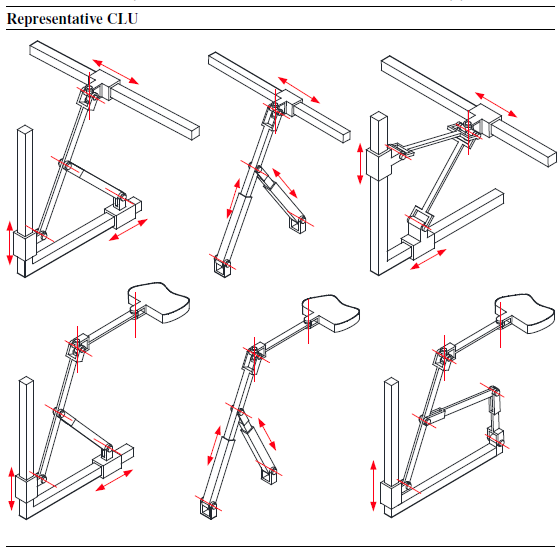
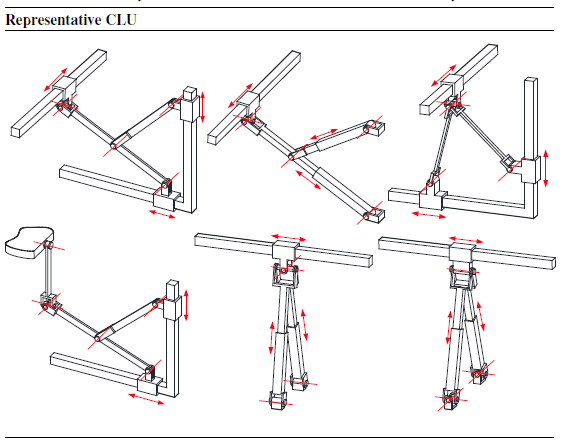
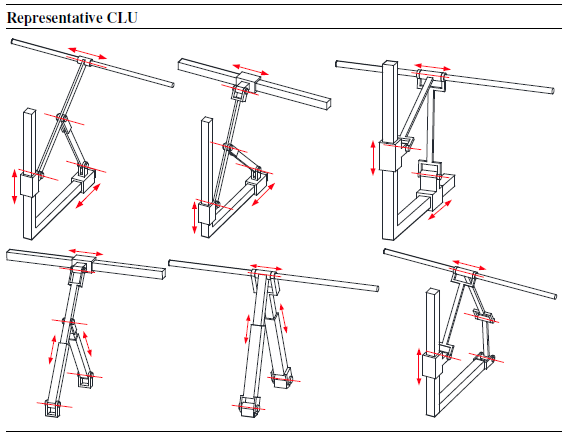
Based on the DOF space and DOF line graph in Table III, the redundantly actuated branched chains with CLU were constructed, as shown in Table IV. Since the DOF space can be decomposed into multiple subspaces of the same dimension, the more types of subspaces of the same dimension there are, the richer the corresponding branch chains with CLU will be. Therefore, this paper selects 24 representative branch chains for display.
Similar to the previous cases, the branch chain DOF space with a y-axis rotational constraint can also be decomposed. According to the line equivalence principle, the translational DOF can be transformed into its rotational counterpart, allowing the branch chain design to be based on both translational and rotational DOFs. Additionally, as shown in Table II, the branch chain DOF space with an x-axis rotational constraint rotates 90° around the z-axis, resulting in the branch chain DOF space with a y-axis rotational constraint. Thus, the branch chains with x-axis rotational constraints in Table IV rotate 90° around the z-axis, resulting in the branch chains constructed from the DOF space with y-axis rotational constraints. As shown in Table V, the number of branch chains is the same as in Table IV (a total of 24 types). This paper selects 6 representative branched chains and shows them in Table V.
Similarly, the branched DOF space with z-axis rotation constraints can be decomposed, and the translational DOFs can be transformed into their corresponding rotational counterparts according to the line equivalence principle. Additionally, the branched DOF space with x-axis rotation constraints is rotated 90° around the y-axis, as shown in Table II, resulting in the branched DOF space with z-axis rotation constraints. Therefore, the branch chains with x-axis rotation constraints (Table IV) are rotated 90° around the y-axis to obtain the branch chains constructed from the DOF space with z-axis rotation constraints, as shown in Table VI. The number of branch chains is the same as in Table IV (24 types in total). This paper selects 6 representative branched chains and shows them in Table VI.
Decomposition and equivalence of the branched chain DOF space constrained by x-axis rotation.

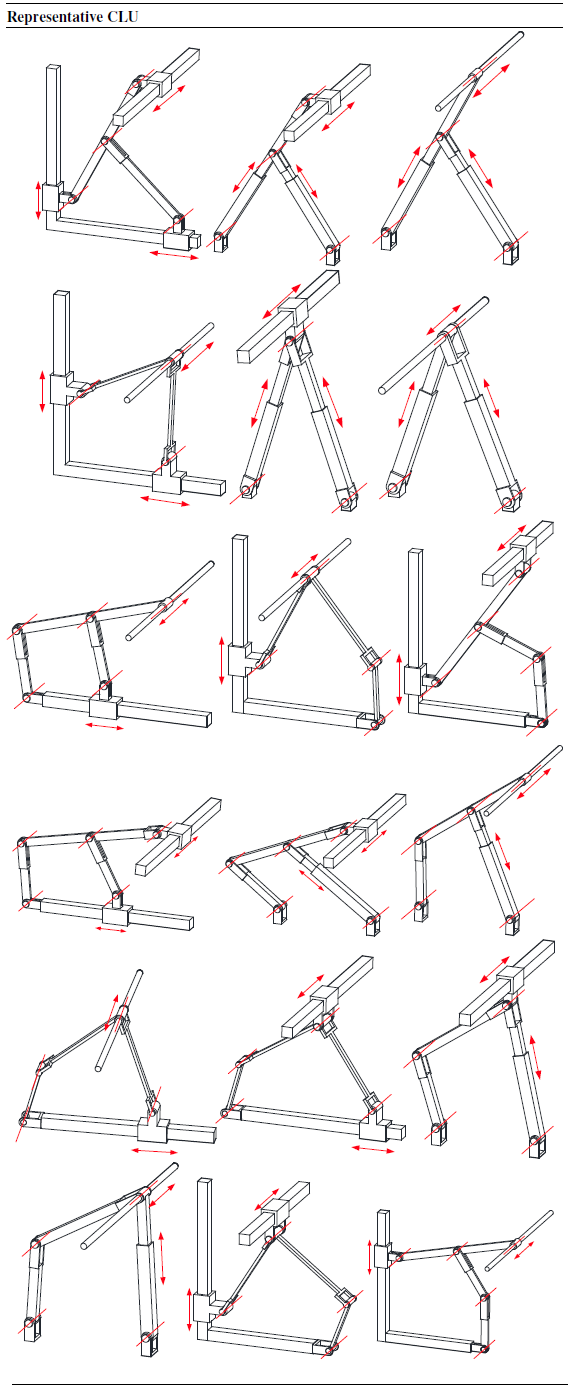
The DOF space constrained by both the x-axis and z-axis rotation can be decomposed. According to the line equivalence principle, the translational DOF can be transformed into the rotational DOF, and the branch chain design is carried out based on both translational and rotational DOFs, as shown in Table VII. The redundantly actuated CLU branched chains are constructed based on the DOF space and DOF line diagrams in Table VII. Table VIII shows 18 representative branched chains.
Similarly, the DOF space constrained by the x-axis and y-axis rotation can be decomposed. Additionally, as shown in Table II, the branched chain DOF space with x-axis and z-axis rotational constraints rotates 90° around the x-axis, resulting in the branched chain DOF space with x-axis and y-axis rotational constraints. Therefore, the branched chains with x-axis and z-axis rotational constraints in Table VIII are rotated 90° around the x-axis to obtain the branched chains constructed in the DOF space constrained by x-axis and y-axis rotation (see Table IX). The number of branched chains is the same as in Table VIII (18 in total). This paper selects 6 representative branched chains and shows them in Table IX.
Similarly, the DOF space of the branched chain with x-axis and z-axis rotational constraints is rotated 90° around the z-axis to obtain the DOF space of the branched chain with y-axis and z-axis rotational constraints. Therefore, the branched chains with x-axis and z-axis rotational constraints in Table VIII are rotated 90° around the z-axis to obtain the branched chains constructed in the DOF space with y-axis and z-axis rotational constraints (see Table X). The number of branched chains is the same as in Table VIII (18 in total). This paper selects 6 representative branched chains and shows them in Table X.
It should be emphasized that the DOF line diagram shown in Table VII, corresponding to rotational constraints about the x- and z-axes, serves as the fundamental reference configuration for the synthesis of branched chains in Tables VIII through X. Thanks to the intuitive and symmetrical representation of constraint directions in the atlas method, the DOF spaces for rotational constraints along the x- and y-axes and y- and z-axes can be logically deduced through 90° structural rotations about the x- and z-axes, respectively. This approach enables the consistent expansion of DOF space representations based on the principle of line equivalence. Although the DOF line diagrams for Tables IX and X are not explicitly illustrated, their synthesis strictly adheres to the same methodology and freedom constraints as established in Tables VII and VIII, ensuring coherence and completeness across all configurations.
Redundantly actuated branched chains with CLU constrained by x-axis rotation.

Given that the branched chain distribution of the PM exhibits geometric symmetry, the mechanism’s stiffness and kinematic properties are improved. Thus, it facilitates subsequent kinematic, dynamic, workspace, and other types of mechanism analyses [Reference Zhang, Huang, Mei and Li35]. In this synthesis method, four branched chains were symmetrically arranged. Based on the constraints in Table II, the number of constraints on each branched chain is either one or two. Considering both the number and distribution requirements of the mechanism’s branched chains, this method categorizes the branch chain selection scheme into two types.
Redundantly actuated branched chains with CLU constrained by y-axis rotation.

In the first scheme, two of the four branched chains have rotational constraints in one direction, share the same structure, and are assembled in opposite directions. Furthermore, the other two branched chains have rotational constraints in the remaining two directions, share the same structure, and are assembled in opposite directions. For example, the first two branched chains have rotational constraints in the x direction, while the remaining two branched chains have rotational constraints in the y and z directions.
In the second scheme, among the four branched chains, two have two rotational constraints, share the same structure, and are assembled in opposite directions. The other two branched chains also have two rotational constraints, share the same structure, and are assembled in opposite directions. The rotational constraint directions of the first two branched chains must differ from those of the second two. For example, if the first two branched chains have rotational constraints along the x and z directions, then the second two must have constraints in the y direction. Therefore, branch chains with rotational constraints along the x and y or y and z directions can be selected.
According to the classification results in Tables IV to X, the number of mechanism configurations for each assembly scheme is determined based on the combinatorial principles defined by their respective constraint arrangements.
Redundantly actuated branched chains with CLU constrained by z-axis rotation.

Decomposition and equivalence of the branched chain DOF space with x-axis and z-axis rotational constraints.

Redundantly actuated branched chains with CLU constrained by x-axis and z-axis rotation.

In the first assembly scheme, four branched chains are employed such that two of them possess single-rotation constraints in the same direction, share identical structures, and are symmetrically assembled in opposite orientations. The other two branched chains provide single-rotation constraints in the remaining two orthogonal directions and are also symmetrically arranged. For example, two chains may constrain rotation about the x-axis, while the others constrain the y- and z-axes, respectively. Based on this structure, and given that 24 types of single-rotation constraint branched chains and 18 types of orthogonal single-rotation pairs are available, the scheme yields exactly 24 × 18 = 432 distinct mechanisms.
In the second assembly scheme, each mechanism consists of two pairs of branched chains. Each pair is composed of two identical branched chains with double-rotation constraints, symmetrically assembled in opposite directions. The rotational constraint directions of the two pairs must differ. For instance, one pair may constrain the x and z directions, while the other constrains y and z. With 18 distinct types of double-rotation constraint branched chains available, this scheme yields exactly 18 × 18 = 324 distinct configurations.
Redundantly actuated branched chains with CLU constrained by x-axis and y-axis rotation.

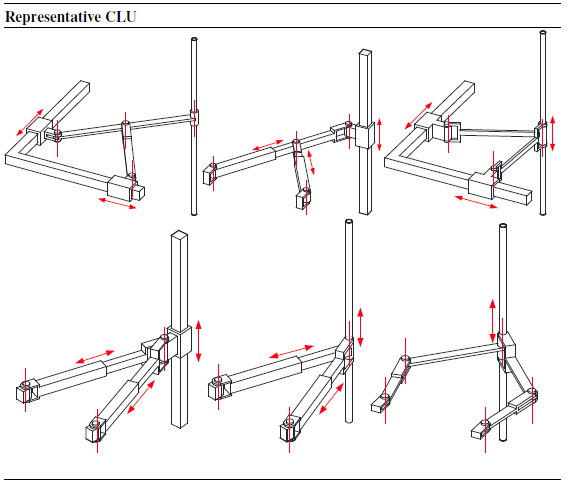
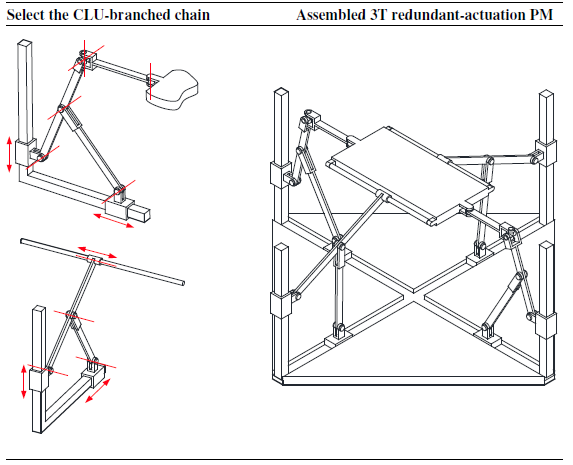
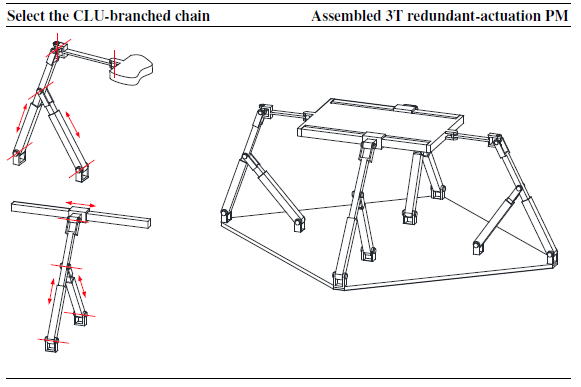
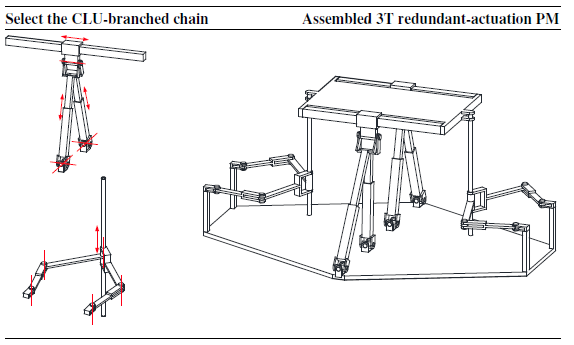
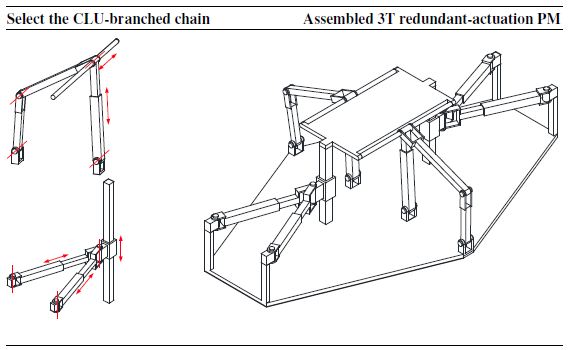
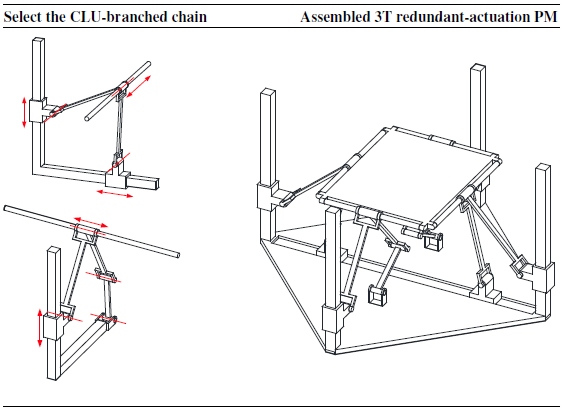
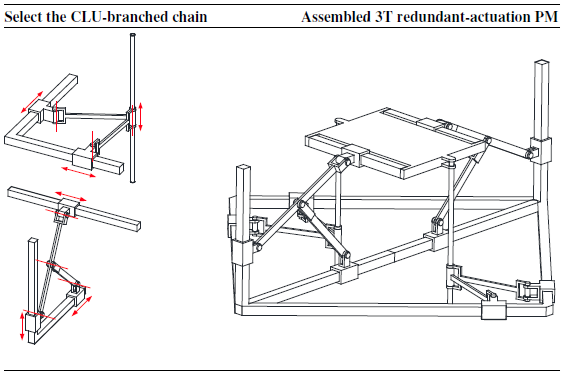
According to the first branch chain selection scheme, the branched chain with an x-direction rotation constraint is selected from Table IV, and the branched chain with y- and z-direction rotation constraints is selected from Table X. The two types of branched chains are symmetrically paired and arranged, as shown in Tables XI and XII.
According to the first branch chain selection scheme, the branched chain with a y-direction rotation constraint is selected from Table V, and the branched chain with x- and z-direction rotation constraints is selected from Table VIII. The two types of branched chains are symmetrically paired and arranged, as shown in Table XIII.
According to the first branch chain selection scheme, the branched chain with a z-direction rotation constraint is selected from Table VI, and the branched chain with x- and y-direction rotation constraints is selected from Table IX. The two types of branched chains are symmetrically paired and arranged, as shown in Table XIV.
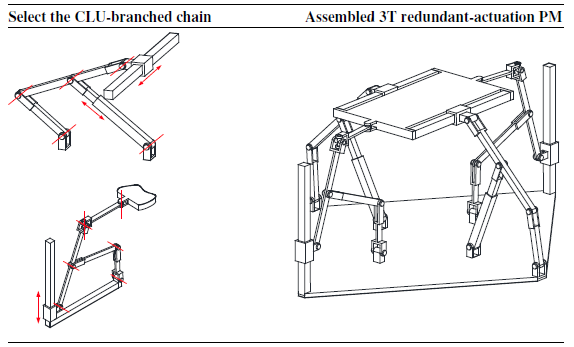
According to the second branch chain selection scheme, the branched chain with rotation constraints in the x and z directions is selected from Table VIII, and the branched chain with rotation constraints in the x and y directions is selected from Table IX. The two types of branched chains are symmetrically paired and arranged, as shown in Table XV.
According to the second branch chain selection scheme, the branched chain with rotation constraints in the x and z directions is selected from Table VIII, and the branched chain with rotation constraints in the y and z directions is selected from Table X. The two types of branched chains are symmetrically paired and arranged, as shown in Table XVI.
Redundantly actuated branched chains with CLU constrained by y-axis and z-axis rotation.

Selected CLU branched chains and the assembled PM.

Selected CLU branched chains and the assembled PM.

According to the second branch chain selection scheme, the branched chain with rotation constraints in the x and y directions is selected from Table IX, and the branched chain with rotation constraints in the y and z directions is selected from Table X. The two types of branched chains are symmetrically paired and arranged, as shown in Table XVII.
5. Analysis of the representative mechanism’s DOF properties
This section analyzes two representative mechanisms synthesized from the proposed assembly schemes (Tables XI–XVII), each incorporating CLU branched chains with different rotational constraint characteristics. Based on screw theory and the atlas method, the analysis investigates the continuity of mechanism motion and verifies whether the synthesized configurations exhibit instantaneous mobility, thereby demonstrating the feasibility and applicability of the proposed synthesis method.
5.1 Analysis of mechanism 1
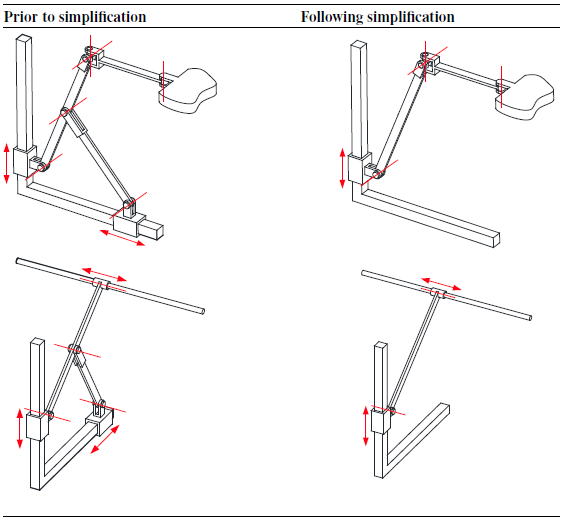
The novel mechanism in Table XI is selected for DOF verification. First, each branched chain of the mechanism is simplified, and the CLU is reduced to an open-loop configuration. The simplified components are then assembled into a parallel mechanism, and its DOF properties are verified using screw theory. The CLU is simplified into an open-loop branched chain before verification, ensuring that the DOF properties of the simplified branched chain remain unchanged, as shown in Table XVIII. The simplified branched chain is assembled to form a 3T redundantly actuated PM with an open-loop configuration, as shown in Figure 6.
Selected CLU branched chains and the assembled PM.

Selected CLU branched chains and the assembled PM.

Verification of the institutional DOF properties using screw theory. The basic kinematic screw system of branched chain 1 is as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{1}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{2}=\left(\begin{array}{lcccccc} 0 & \quad 1 & \quad 0 & \quad ; & \quad -b & \quad 0 & \quad -a \end{array}\right)\\[2pt] \boldsymbol{\$ }_{3}=\left(\begin{array}{lcccccc} 0 & \quad 1 & \quad 0 & \quad ; & \quad -d & \quad 0 & \quad -c \end{array}\right)\\[2pt] \boldsymbol{\$ }_{4}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 1 & \quad ; & \quad 0 & \quad c & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{5}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 1 & \quad ; & \quad 0 & \quad e & \quad 0 \end{array}\right) \end{array} \end{equation*}$
Selected CLU branched chains and the assembled PM.

Selected CLU branched chains and the assembled PM.

Furthermore, the constraint screw of branched chain 1 is as follows:
 $ \begin{equation*} \boldsymbol{\$ }_{1}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right) \end{equation*}$
Selected CLU branched chains and the assembled PM.

Simplify the CLU branched chain.

The basic kinematic screw system of branched chain 2 is as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{6}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{7}=\left(\begin{array}{lcccccc} 1 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad g & \quad f \end{array}\right)\\[2pt] \boldsymbol{\$ }_{8}=\left(\begin{array}{lcccccc} 1 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad d & \quad h \end{array}\right)\\[2pt] \boldsymbol{\$ }_{9}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right) \end{array} \end{equation*}$
The constraint screw of branched chain 2 is as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{2}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{3}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right) \end{array} \end{equation*}$
Since branched chains 3 and 4 are symmetric to branched chains 1 and 2, their constraint screws are identical to those of chains 1 and 2, respectively. Therefore, the constraint screw system of the moving platform is defined as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{1}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{2}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{3}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{4}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{5}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{6}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right) \end{array} \end{equation*}$
The three constraint screws described above represent coupled constraints in the x, y, and z directions; therefore, the mechanism loses three rotational DOFs. From the reciprocity relation of the screws, the motion screw can be derived as:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{1}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{2}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{3}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right) \end{array} \end{equation*}$
The above kinematic screws represent translational DOFs along the x, y, and z directions, hence a 3T mechanism.
5.2 Analysis of mechanism 2
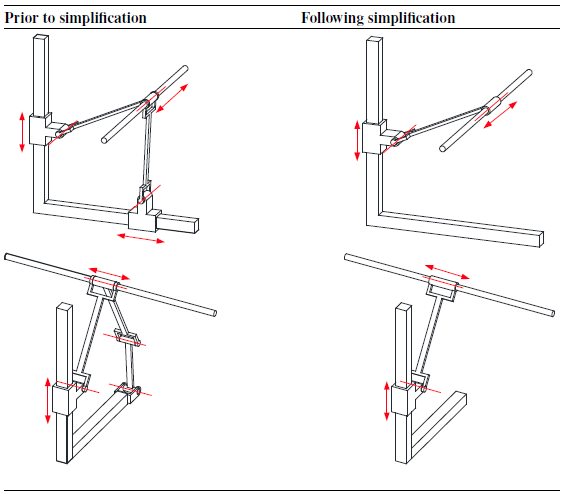
The novel mechanism in Table XVI is selected for DOF verification. As shown in Table XIX, the CLU is simplified into an open-loop branched chain before validation, and it can be observed that the DOF properties of the simplified branched chain remain unchanged. Similarly, the simplified branched chain is assembled into a 3T redundantly actuated PM with an open-loop configuration, as shown in Figure 7.
Verification of the institutional DOF properties using screw theory. The basic kinematic screw system of branched chain 1 is as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{1}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{2}=\left(\begin{array}{lcccccc} 0 & \quad 1 & \quad 0 & \quad ; & \quad -b & \quad 0 & \quad -a \end{array}\right)\\[2pt] \boldsymbol{\$ }_{3}=\left(\begin{array}{lcccccc} 0 & \quad 1 & \quad 0 & \quad ; & \quad -d & \quad 0 & \quad -c \end{array}\right)\\[2pt] \boldsymbol{\$ }_{4}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right) \end{array} \end{equation*}$
Furthermore, the constraint screw of branched chain 1 is as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{1}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{2}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right) \end{array} \end{equation*}$
Simplified 3T redundantly actuated PM.

Simplify the CLU branched chain.

The basic kinematic screw system of branched chain 2 is as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{5}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{6}=\left(\begin{array}{lcccccc} 1 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad f & \quad e \end{array}\right)\\[2pt] \boldsymbol{\$ }_{7}=\left(\begin{array}{lcccccc} 1 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad d & \quad g \end{array}\right)\\[2pt] \boldsymbol{\$ }_{8}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right) \end{array} \end{equation*}$
The constraint screw of branched chain 2 is as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{3}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{4}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right) \end{array} \end{equation*}$
Since branched chains 3 and 4 are symmetric to branched chains 1 and 2, their constraint screws are identical to those of chains 1 and 2, respectively. Therefore, the constraint screw system of the moving platform is defined as follows:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{1}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{2}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{3}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{4}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{5}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{6}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{7}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{8}^{r}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right) \end{array} \end{equation*}$
The three constraint screws described above represent coupled constraints in the x, y, and z directions; therefore, the mechanism loses three rotational DOFs. From the reciprocity relation of the screws, the motion screw can be derived as:
 $ \begin{equation*} \begin{array}{l} \boldsymbol{\$ }_{1}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 1 & \quad 0 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{2}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 1 & \quad 0 \end{array}\right)\\[2pt] \boldsymbol{\$ }_{3}=\left(\begin{array}{lcccccc} 0 & \quad 0 & \quad 0 & \quad ; & \quad 0 & \quad 0 & \quad 1 \end{array}\right) \end{array} \end{equation*}$
The above kinematic screw represents translational DOFs along the x, y, and z directions, making it a 3T mechanism.
Simplified 3T redundantly actuated PM.

5.3 Instantaneous analysis of mechanisms 1 and 2
The moving platforms of Mechanisms 1 and 2 are translated along the x-, y-, and z-axes, respectively. Figure 8(a) and (b) present the force couple constraint lines after the platforms are translated in the directions of the three coordinate axes. Since free vectors are independent of position, any two free vectors can intersect after translation. Therefore, the force couple constraint lines in Figure 8(a) and (b) can be regarded as three linearly independent couples. According to the principles of Grassmann line geometry [Reference Meng, Xie, Tang and Liu32, Reference Wen, Seo and Lee37], the rank of the constraint space is always 3. Thus, both mechanisms 1 and 2 consistently exhibit three translational degrees of freedom, indicating that they do not possess instantaneous characteristics during motion [Reference Zhang, Xu and Li38, Reference Zheng, Zhang, Wang, Li and Zhang39].
Instantaneous analysis of mechanisms 1 and 2.

6. Discussion
The synthesis approach introduced in this paper provides a certain degree of progress in the design of 3T redundant actuated PMs with CLUs. A key advantage of these synthesized mechanisms over traditional 3T PMs is their structural stiffness and load-carrying capacity, achieved through the integration of internal closed-loop constraint paths. Unlike conventional 3T PMs composed of open-loop branched chains, which may suffer from uneven load distribution and susceptibility to deformation under dynamic loads, the closed-loop architecture introduced here offers greater rigidity, more uniform force distribution, and enhanced dynamic stability [Reference Jin, Fang and Zhang40, Reference Tian, Fang and Ge41]. Consequently, these mechanisms are particularly suitable for demanding industrial tasks such as high-speed sorting, precise robotic assembly, or scenarios requiring high dynamic stability and high payload capacity.
In addition, the use of redundant actuation in the synthesized mechanisms provides extra actuation inputs beyond the minimal requirement, which enables enhanced flexibility in control. This additional actuation facilitates the avoidance of internal singularities within the workspace through coordinated actuator strategies, thereby improving motion continuity. Redundancy in actuation can also offer tolerance to actuator failure, contributing to system robustness in applications that demand high reliability. While redundant actuation is not novel in itself, its integration with closed-loop branched chains in the context of 3T PMs expands the range of feasible configurations and applications.
From a theoretical perspective, this study addresses a fundamental methodological limitation encountered in previous research. While our prior work [Reference Li, Zhang and Zhang6] successfully employed the atlas method to synthesize redundantly actuated 2R1T and 2T1R PMs with CLUs by introducing redundant lines into constraint diagrams, attempts to directly apply this same approach to 3T redundantly actuated PMs proved ineffective. The core difficulty arises because, in 3T PMs, the constraint couple quantities behave as free vectors independent of spatial position, rendering the straightforward addition of redundant lines invalid for generating viable CLU structures. To overcome this challenge, the present study introduces the principle of line equivalence into the atlas method framework. By extending the DOF line diagrams, this enhanced approach enables the successful and systematic synthesis of structurally diverse yet DOF-equivalent branched chains containing valid CLUs. Therefore, the method introduced in this paper further completes the atlas method for synthesizing 3T redundant actuated PMs with CLUs, offering a consistent and efficient solution to a previously unresolved theoretical challenge and enriching the available design configurations.
7. Conclusion
This paper introduces a synthesis method for 3T redundant actuated PMs with CLU based on the atlas method. The principle of line equivalence is applied to expand the CLU-equivalent DOF line diagram, enabling the synthesis of various novel types of CLU-branched chains, thereby enriching the types of CLU and expanding the configurations of 3T redundant actuated PMs containing CLU. Considering the geometrically symmetric configuration criterion for branched chain distribution, CLU-redundant actuated branched chains with various constraint types are refined. Two assembly schemes for 3T redundant actuated PMs with CLU are proposed, yielding at least 432 and 324 novel configurations, respectively. Two representative mechanisms are selected, and their DOF properties are analyzed using screw theory, confirming the validity of the synthesis method.
While this study primarily focuses on topological synthesis, we sincerely recognize that multi-limb and multi-loop couplings introduce substantial complexity that may significantly influence key performance indicators such as workspace volume, dexterity, and structural rigidity. Although these performance metrics are not evaluated in the present work, they represent an essential direction for future research. Existing analytical frameworks – such as boundary-based workspace computation [Reference He, Fang, Jin and Zhang42], singularity mapping [Reference Simas and Di Gregorio43], manipulability assessment [Reference Li, Tian, Xia and Zhang44], and kinetostatic modeling [Reference Liu, Ruan, Lu, Weng, Wu and Zheng45] – provide a solid foundation for such investigations. In future studies, we will employ these methods to quantitatively evaluate selected synthesized mechanisms and to characterize the geometric and dynamic performance of multi-loop, multi-limb configurations. These analyses will offer a rigorous basis for validating the applicability and mechanical feasibility of the proposed mechanisms in practical engineering scenarios.
Author contributions
Tianyu Zheng wrote the manuscript. Xiaojun Zhang provided financial support and conceptual design. Yongquan Li provided the conceptual design. All authors read and approved the final manuscript.
Financial support
This work was supported by the National Natural Science Foundation of China [grant number 52275017], the Natural Science Foundation of Hebei Province of China [grant number E2024202138], and the Chinese Science and Technology Development Fund project on Central Government Guiding Local Government [grant numbers 236Z1806G and 226Z1801G].
Competing interests
The authors declare no conflicts of interest exist.
Ethical approval
Not applicable.