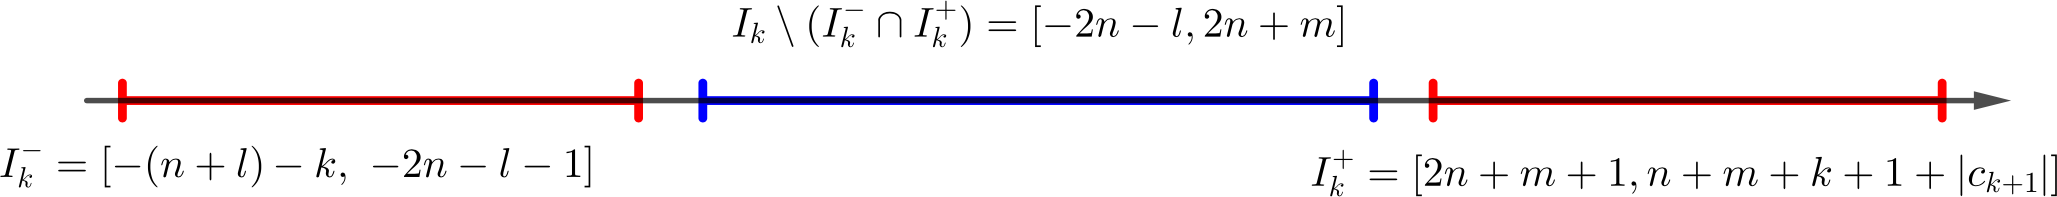1 Introduction
Dynamically defined Lagrange and Markov spectra are subsets of the real line used to quantify the asymptotic behavior of the orbits of a given dynamical system. By considering the level curves associated to a reference real function, these spectra store the asymptotic and maximum height of different orbits of the system asymptotically. More precisely, for a dynamical system
 $\varphi $
from a metric space X to itself and a continuous function
 $f:X\to \mathbb {R}$
, the dynamically defined Lagrange and Markov spectra associated to the data
 $(\varphi ,\, f)$
is given by the sets
 $$ \begin{align*} L(\varphi,\, f) = \Big\{\kern-3pt \limsup_{j\to\infty}\, f(\varphi^j(x))\colon\, x\in X \Big\} \quad \text{and} \quad M(\varphi,\, f) = \Big\{\kern-3pt \sup_{j\in \mathbb{Z}}\, f(\varphi^j(x))\colon\, x\in X \Big\}. \end{align*} $$
In geometric terms, the Lagrange spectrum can be seen as the set of values (or heights) for which the respective level curves are asymptotically accumulated by orbits of the phase space. Similarly, the Markov spectra collects the biggest heights from different orbits of the system.
A special case stands out in the number theoretical context in which the data
 $(\varphi ,\, f)$
in consideration are given by the shift map
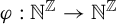 $\varphi :\mathbb {N}^{\mathbb {Z}} \to \mathbb {N}^{\mathbb {Z}}$
and the real function
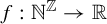 $f:\mathbb {N}^{\mathbb {Z}}\to \mathbb {R}$
defined by
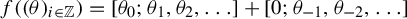 $f((\theta )_{i\in \mathbb {Z}}) = [\theta _0; \theta _1, \theta _2, \ldots ]+[0; \theta _{-1}, \theta _{-2}, \ldots ]$
, where the expression
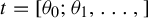 $t = [\theta _0; \theta _1,\ldots , ]$
represents the expansion of the real number t in continued fraction.
The dynamically defined Lagrange and Markov spectra associated to this data coincides with the (classical) Lagrange and Markov spectra M and L. These classical spectra originally appeared from analyzing Diophantine properties of real numbers. The study of their structure dates back to the nineteenth century (see [Reference Markoff21, Reference Markoff22]) and many contributions have been made to the topic since then.
It is known that
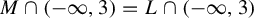 $M\cap (-\infty ,3) = L\cap (-\infty ,3)$
is a discrete set with
 $3$
as the sole accumulation point (see [Reference Markoff21, Reference Markoff22]). Moreover, there exists an (optimal) constant
 $c_F>3$
with the property that
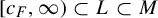 $[c_F,\infty )\subset L\subset M$
(see [Reference Freiman15, Reference Hall16]). The fractal properties of these spectra between
 $3$
and
 $c_F$
has been a theme of active research from the last 60 years. Moreira, in [Reference Moreira23], showed that the Hausdorff dimension of sets
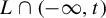 $L\cap (-\infty , t)$
and
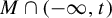 $M\cap (-\infty , t)$
is not a differentiable function of the parameter
 $t\in \mathbb {R}$
. Furthermore, in [Reference Moreira23], the positivity of the Hausdorff dimension of these spectra, around any small interval around
 $3$
, is also established. This result was later improved in [Reference Erazo, Gutiérrez-Romo, Moreira and Romana13], where the precise modulus of continuity of the function
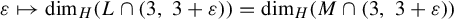 $\varepsilon \mapsto \operatorname {dim}_H(L\cap (3,\, 3+\varepsilon )) = \operatorname {dim}_H(M\cap (3,\, 3 + \varepsilon ))$
was provided.
Studying the points that belong to the classical Markov spectrum but are not in the Lagrange spectrum has a central role in the theory. Indeed,
 $M\backslash L$
has a complicated fractal structure, and the precise estimation of its Hausdorff dimension is still far from being achieved (see [Reference Lima, Matheus, Moreira and Romana18] for a comprehensive discussion on the structure of
 $M\backslash L$
). Regarding the analysis of the set of real numbers possessing the same Lagrange value or equivalently, the study of the ‘level sets of the classical Lagrange spectrum’, Moreira and Villamil, in [Reference Moreira and Villamil24], proved that for each given value t in the interior of L, the Hausdorff dimension of the set of real numbers whose Lagrange value belongs to
 $(-\infty , t)$
coincides with the Hausdorff dimension of the level set associated to t.
One of the main approaches to extracting properties of the classical spectra comes from the characterization of these sets in different contexts [Reference Arnoux1, Reference Ford14, Reference Lima, Matheus, Moreira and Romana18, Reference Nicholls26, Reference Perron30]. The definition of the dynamically defined Markov and Lagrange spectra presented here relies on Perron’s characterization of the classical spectra using the orbits of a shift over a countable alphabet. This work is inspired in the smooth characterization of these spectra and the main question that we address is the following:
-
• For typical smooth data, is the complexity of the dynamically defined Lagrange and Markov spectra a sufficient indication of the complexity of the system?
The following dichotomy ensures that the information on the complexity of the Lagrange spectrum is indeed enough to secure the complexity of the underlying dynamical system. A diffeomorphism is Morse–Smale if the chain recurrent set is hyperbolic and finite.
Theorem A. Let M be a compact manifold. Then, there exists a
 $C^1$
-open and
 $C^1$
-dense subset
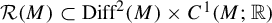 $\mathcal {R}(M)\subset \operatorname {Diff}^{2}(M)\times C^1(M;\mathbb {R})$
such that if
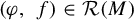 $(\varphi ,\, f)\in \mathcal {R}(M)$
, then either:
-
(1)
 $L(\varphi ,\, f)$
is finite and
$\varphi $
is a Morse–Smale diffeomorphism; or
-
(2)
$L(\varphi ,\, f)$
has positive Hausdorff dimension and
$h_{\text {top}}(\varphi )>0$
.


Therefore, at least generically, if the Hausdorff dimension of the Lagrange spectrum is positive (complexity of the spectrum), we should expect our system to have positive entropy (complexity of the system). However, the Markov spectrum differs significantly. In any compact manifold, it is possible to build examples of open sets of data where the dynamics remains predictable; however, the Markov spectrum contains intervals.
Theorem B. Let M be a compact manifold. Then, there exists an open subset
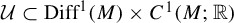 $\mathcal {U}\subset \operatorname {Diff}^1(M)\times C^1(M;\mathbb {R})$
such that for every
 $(\varphi , f) \in \mathcal {U}$
, we have that
 $L(\varphi ,\, f)$
is finite and
 $M(\varphi ,\, f)$
has non-empty interior.
Crovisier in [Reference Crovisier9] proved that a typical diffeomorphism in the
 $C^1$
-topology is either a Morse–Smale diffeomorphism or admits a horseshoe. Using this fact, it is enough for our purposes to analyze the Lagrange spectrum for typical data in which the dynamical system admits a horseshoe or, equivalently, a transversal homoclinic intersection associated to a hyperbolic periodic point of saddle-type.
Exploring the nice geometric properties of horseshoes for surface diffeomorphisms, Moreira and Romanã obtained in [Reference Romaña Ibarra and de A. Moreira33] that both spectra have non-empty interior for typical diffeomorphisms with a ‘thick’ surface horseshoe
 $\Lambda $
(
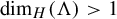 $\operatorname {dim}_H(\Lambda )> 1$
) and for a typical real function. In the case of a ‘thin’ surface horseshoe
 $\Lambda $
, meaning
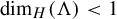 $\operatorname {dim}_H(\Lambda ) < 1$
, Cerqueira, Matheus, and Moreira in [Reference Cerqueira, Matheus and Moreira7] approached the problem of continuity of the maps
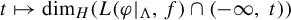 $t\mapsto \operatorname {dim}_H(L(\varphi |_{\Lambda }, f)\cap (-\infty ,\, t))$
and
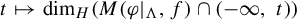 $t\mapsto \operatorname {dim}_H(M(\varphi |_{\Lambda }, f)\cap (-\infty ,\, t))$
. They obtained continuity of these functions for typical smooth systems
 $\varphi $
and typical real function f. In the area-preserving case, they additionally obtained that typically
 $$ \begin{align*} \operatorname{dim}_H(L(\varphi|_{\Lambda}, f)\cap (-\infty,\, t)) = \operatorname{dim}_H(M(\varphi|_{\Lambda}, f)\cap (-\infty,\, t)) \end{align*} $$
(see also [Reference Cerqueira, Moreira and Romaña8] for a similar result in the context of geodesic flow on negatively curved surfaces). The thin assumption on the horseshoe was later removed by Lima, Moreira, and Villamil in [Reference Lima, Moreira and Villamil20].
We may regard the dynamically defined Markov and Lagrange spectra for smooth systems as a model that allows us to identify properties in these sets that are difficult to determine in the classical setting. An example of this property is the phase transition of the dynamical spectral obtained by Lima and Moreira in [Reference Lima and Moreira19] for typical conservative systems. The phase-transition property is characterized by the existence of a parameter
 $t^*$
such that for any
 $\delta>0$
, the portion of both spectra inside of the interval
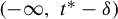 $(-\infty ,\, t^* - \delta )$
has Hausdorff dimension smaller than one; however, just after
 $t^*$
, we observe non-empty interior within the spectrum.
Leaving the surface setting, much less is known. The relevant geometrical properties presented in the two-dimensional case are no longer valid for general higher-dimensional systems. Nevertheless, it is possible to perform local constructions to design, after perturbation, such hyperbolic sets presenting the desired geometric features. This approach was followed by Palis and Viana in [Reference Palis and Viana28] to investigate the presence of infinitely many coexisting sinks in dissipative systems.
Combining the construction in [Reference Palis and Viana28] with an adaptation of the techniques developed in [Reference Romaña Ibarra and de A. Moreira33], in this work, we prove the following result.
Theorem C. Let M be a compact manifold of dimension
 $d\geq 2$
. Let
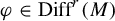 $\varphi \in \operatorname {Diff}^r(M)$
,
 $r\geq 2$
, admitting a transversal homoclinic intersection. Then, there exist
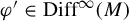 $\varphi '\in \operatorname {Diff}^{\infty }(M)$
,
 $C^r$
-close to
 $\varphi $
and a
 $C^1$
-open neighborhood of
 $\varphi '$
,
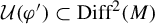 $\mathcal {U}(\varphi ')\subset \operatorname {Diff}^2(M)$
such that for every
 $\tilde {\varphi }\in \mathcal {U}(\varphi ')$
, there exists an open and dense set,
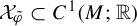 $\mathcal {X}_{\tilde {\varphi }}\subset C^1(M;\mathbb {R})$
, of real functions such that if
 $f\in \mathcal {X}_{\tilde {\varphi }}$
, then both
 $M(\Lambda _{\tilde {\varphi }},\, f)$
and
 $L(\Lambda _{\tilde {\varphi }},\, \varphi )$
have positive Hausdorff dimension.
In §2, we introduce the notation and establish the preliminary results that will be used throughout the work. In §3, we analyze the dynamically defined Lagrange spectrum associated to subshifts of finite type. The choice of the generic set of pairs that will be used in the proof of Theorem C is provided in §4. Section 5 contains the proof of Theorems A, B, and C.
2 Preliminaries
In this section, we introduce the basic tools that will be used in the work.
2.1 Dynamically defined Markov and Lagrange spectra
Let X be a metric space and
 $\varphi :X\to X$
be a homeomorphism. Let
 $\Lambda $
be a
 $\varphi $
-invariant compact subset of X and let
 $f:X\to \mathbb {R}$
be a continuous function. The dynamically defined Lagrange and Markov spectra over
 $\Lambda $
is given respectively by the sets
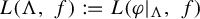 $L(\Lambda ,\, f):= L(\varphi |_{\Lambda },\, f)$
and
 $M(\Lambda ,\, f) := M(\varphi |_{\Lambda },\, f)$
. It is straightforward to see that
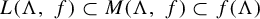 $L(\Lambda ,\, f)\subset M(\Lambda ,\, f)\subset f(\Lambda )$
.
Notice that if the limit set of
 $\varphi |_{\Lambda }$
is finite, then
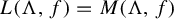 $L(\Lambda ,f) = M(\Lambda , f)$
is trivially finite, independently of the chosen potential f. The class of Morse–Smale diffeomorphisms fits in this exact scenario.
Nevertheless, in many situations, these spectra can have a very complicated fractal structure. An important example comes from the theory of Diophantine approximations and quadratic forms as follows. Define the best constant of Diophantine approximation of a real number
 $\alpha>0$
by
 $$ \begin{align*} k(\alpha) = \sup \bigg\{ k>0\colon\, \bigg|\alpha-\dfrac{p}{q}\bigg|<\dfrac{1}{kq^2} \text{ has infinitely many solutions } \dfrac{p}{q} \in \mathbb{Q} \bigg\}. \end{align*} $$
The classical Lagrange spectrum L is the set formed by the quantities
 $k(\alpha )$
with
 $k(\alpha )<\infty $
. The classical Markov spectrum is defined as the set
 $$ \begin{align*} M = \Big\{ \Big(\inf_{(x,y) \in \mathbb{Z}^2 \setminus (0,0)} |f(x,y)|\Big)^{-1}\colon\, f(x,y)=ax^2+bxy+cy^2 \text{, with } b^2-4ac=1 \Big\}. \end{align*} $$
The link between the classical notions and the dynamical setting is provided by the following characterization due to Perron [Reference Perron30]. Let
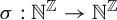 $\sigma : \mathbb {N}^{\mathbb {Z}} \to \mathbb {N}^{\mathbb {Z}}$
be the shift map and
 $f: \Sigma \to \mathbb {R}$
be a continuous function given by
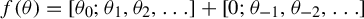 $f(\theta )=[\theta _0; \theta _1, \theta _2, \ldots ]+[0; \theta _{-1}, \theta _{-2}, \ldots ]$
,
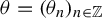 $\theta = (\theta _n)_{n\in \mathbb {Z}}$
. Then,
 $$ \begin{align*} L = L(\sigma,\, f) \quad \text{and} \quad M = M(\sigma,\, f). \end{align*} $$
It is also possible to characterize the classical Markov and Lagrange spectrum from a smooth setting. Indeed, consider
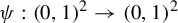 $\psi :(0,1)^2 \to (0,1)^2$
defined by
 $$ \begin{align*}\psi (x,y) =\bigg(\bigg\{ \dfrac{1}{x}\bigg\}, \dfrac{1}{\lfloor 1/x\rfloor+y} \bigg),\end{align*} $$
where
 $\{1/x\}$
is the fractional part of
 $1/x$
and
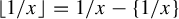 $\lfloor 1/x\rfloor = 1/x - \{1/x\}$
. Define the set
 $C_N=\{[0;a_1, a_2, \ldots ]: \; 1 \leq a_n \leq N\}$
and so
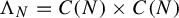 $\Lambda _N=C(N) \times C(N)$
is a compact
 $\psi $
-invariant subset of
 $(0,1)^2$
. Given
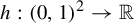 $h: (0,1)^2 \to \mathbb {R}$
defined by
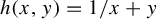 $h(x,y)=1/x+y$
, we have
 $$ \begin{align*} L\cap (-\infty, N)=L(\Lambda_N,\, h)\cap (-\infty, N) \quad \text{and} \quad M\cap (-\infty, N)=M(\Lambda_N,\, h)\cap (-\infty, N). \end{align*} $$
Another important example of classical spectrum is the Dirichlet spectrum
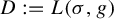 $D := L(\sigma , g)$
, where
 $g: \Sigma \to \mathbb {R}$
is given by
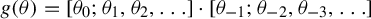 $g(\theta )=[\theta _0; \theta _1, \theta _2, \ldots ]\cdot [\theta _{-1}; \theta _{-2}, \theta _{-3}, \ldots ]$
. Motivated by arithmetical considerations, Davenport and Schmidt introduced the Dirichlet spectrum in [Reference Davenport and Schmidt11]. They also established the above dynamical characterization. The spectrum D may furthermore be described in the smooth setting. Indeed, choosing
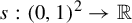 $s: (0,1)^2 \to \mathbb {R}$
,
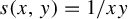 $s(x,y)=1/xy$
, we see that
 $$ \begin{align*} D\cap (-\infty, N)=L(\Lambda_N,\, s)\cap (-\infty, N), \end{align*} $$
with
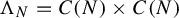 $\Lambda _N = C(N)\times C(N)$
as above. See [Reference Lima, Matheus, Moreira and Romana18] for a detailed discussion on the Dirichlet spectrum.
2.2 Horseshoes
Unless otherwise stated, in this article, M denotes a smooth d-dimensional compact Riemannian manifold with
 $d\geq 2$
. We write
 $\operatorname {Diff}^r(M)$
to denote the space of diffeomorphisms from M to M of class
 $C^r$
, where
 $r\in [1,\infty ]$
.
2.2.1 Horseshoes and holonomies
Consider
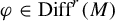 $\varphi \in \operatorname {Diff}^r(M)$
,
 $r\in [1,\infty ]$
. We say that a
 $\varphi $
-invariant compact set
 $\Lambda \subset M$
is hyperbolic if there exists a decomposition of the tangent bundle of
 $\Lambda $
into two continuous,
 $D\varphi $
-invariant, sub-bundles
 $E^s$
and
 $E^u$
, that is,
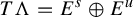 $T\Lambda = E^s\oplus E^u$
, and there exist constants
 $C>0$
and
 $\unicode{x3bb} \in (0,1)$
such that
 $$ \begin{align*} \lVert D\varphi^n(x)|_{E^s(x)}\rVert\leq C\unicode{x3bb}^n \quad\text{and}\quad \lVert D\varphi^{-n}(x)|_{E^u(x)}\rVert\leq C\unicode{x3bb}^n \end{align*} $$
for every
 $n\geq 0$
and every
 $x\in \Lambda $
. A hyperbolic set
 $\Lambda $
is a horseshoe for
 $\varphi $
if
 $\Lambda $
is infinite, totally disconnected, transitive and
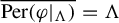 $\overline {\operatorname {Per}(\varphi |_{\Lambda })} = \Lambda $
.
An important feature ensured by the hyperbolic structure in the set
 $\Lambda $
is the existence of stable and unstable laminations. More precisely, for each point
 $x\in \Lambda $
, there exists a pair of traversal
 $\varphi $
-invariant, immersed
 $C^r$
-submanifolds
 $W^s(x)$
and
 $W^u(x)$
, which are tangent to
 $E^s(x)$
and
 $E^u(x)$
at x, respectively. These are called stable and unstable manifolds of
 $\varphi $
at x. The stable lamination of
 $\Lambda $
,
 $W^s(\Lambda )$
, is defined as the collection of
 $W^s(x)$
, with
 $x\in \Lambda $
. Analogously, we define the unstable lamination of
 $\Lambda $
,
 $W^u(\Lambda )$
.
For
 $C^1$
-diffeormorphisms, the stable manifold theorem [Reference Shub35] ensures that the stable and unstable manifolds are locally embedded disks of dimension
 $\operatorname {dim} E^s$
and
 $\operatorname {dim} E^u$
, respectively. Moreover, for any positive small
 $\delta $
and any point
 $x\in \Lambda $
, if we denote by
 $W^s_{\delta }(x)$
(
 $W^u_{\delta }(x)$
) the set of points
 $y\in W^s(x)$
(
 $y\in W^u(x)$
) with
 $d(x,y)<\delta $
(d is the distance associated to a Riemannian structure on M), then the maps that associate to each
 $x\in \Lambda $
, the local stable manifold
 $W^s_{\delta }(x)$
(the local unstable manifold
 $W^u_{\delta }(x)$
), are continuous. In other words, we have continuity of the stable and unstable laminations.
If the diffeomorphism is
 $C^r$
, with
 $r>1$
, Pugh, Shub, and Wilkinson in [Reference Pugh, Shub and Wilkinson31] proved that the stable and unstable laminations are Hölder continuous. Nevertheless, there are examples of diffeomorphisms with horseshoe for which these laminations are not even Lipschitz (see [Reference Palis and Viana28, §3]).
Higher regularity of the laminations is particularly useful when analyzing the fractal properties of the horseshoes. Indeed, the fact that a horseshoe
 $\Lambda $
is locally homeomorphic to products of the form
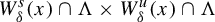 $W^s_{\delta }(x) \cap \Lambda \times W^u_{\delta }(x) \cap \Lambda $
highlights that higher regularity of the laminations ensures a certain degree of ‘fractal homogeneity’. Thus, to understand
 $\Lambda $
at small scales, it is enough to concentrate our analysis on the structure of the stable and unstable Cantor sets
 $W^s_{\delta }(x)\cap \Lambda $
,
 $W^u_{\delta }(x)\cap \Lambda $
, in any point
 $x\in \Lambda $
.
When the ambient manifold M is two-dimensional, we may extend the stable and unstable laminations to
 $C^{1+\alpha }$
-foliations in a neighborhood of
 $\Lambda $
, see [Reference Palis and Takens27]. This extension is the initial technical step for the study of two-dimensional systems presenting highly relevant dynamical phenomena (see for example, [Reference Moreira and Yoccoz25, Reference Palis and Takens27, Reference Palis and Yoccoz29] and references therein).
The regularity of the stable and unstable lamination is intrinsically related to the regularity of the holonomy maps defined by these laminations (see the discussion in [Reference Pugh, Shub and Wilkinson31]). Unstable holonomies are defined as follows: for
 $x_0, y_0\in \Lambda $
with
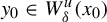 $y_0\in W^u_{\delta }(x_0)$
, set
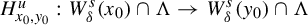 $H^u_{x_0,y_0}: W^s_{\delta }(x_0)\cap \Lambda \to W^s_{\delta }(y_0)\cap \Lambda $
as the map that maps each
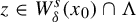 $z\in W^s_{\delta }(x_0)\cap \Lambda $
into the unique intersection point
 $H^u_{x_0,y_0}(z)$
between
 $W^u_{\delta }(z)$
and
 $W^s_{\delta }(y_0)$
. The local product structure of the horseshoe
 $\Lambda $
ensures that
 $H^u_{x_0,y_0}$
is well defined and that
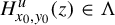 $H^u_{x_0,y_0}(z)\in \Lambda $
. Analogously, we may define stable holonomies.
2.2.2 Regular Cantor sets
A compact set
 $K\subset \mathbb {R}$
is a regular Cantor set if there exist
 $\gamma>0$
, a cover of K by disjoint intervals
 $I_1,\dots ,I_k$
and a
 $C^{1+\gamma }$
expanding function
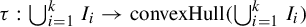 $\tau :\bigcup _{i=1}^kI_i\rightarrow \text {convexHull}(\bigcup _{i=1}^kI_i)$
satisfying that:
-
(1)
$|\tau '(t)|>1$
for every
$t\in I_j$
and for every
$j=1,\dots , k$
; -
(2) for every
$1\leq j\leq k$
and every n sufficient large,
$\tau ^n(I_j) \supset \bigcup _{i=1}^kI_i$
; -
(3) for every
$1\leq j \leq k$
, there exists
$F_j\subset \{1,\ldots , k\}$
such that
$\tau (I_j)$
is the convex-hull of (
$\bigcup _{i\in F_j} I_i$
); -
(4)
$K = \bigcap _{n\geq 0}\tau ^{-n}(\bigcup _{i=1}^{k} I_i)$
.



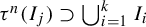

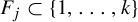


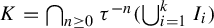
In [Reference Palis and Takens27], we can see that if K is a regular Cantor set, then
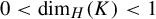 $0< \operatorname {dim}_H(K)<1$
. The same is not true if we extend the notion of regular Cantor sets allowing the map
 $\tau $
to be taken as
 $C^1$
(see [Reference Bowen4]). Another important feature of regular Cantor sets is that its Hausdorff dimension varies continuously with respect to the expanding map
 $\tau $
.
We say that a compact set X has a Cantor set structure if there exists an
 $IC^{1+\alpha }$
invertible map (see definition in §2.4)
 $g:X\to K$
from X onto a regular Cantor set K with
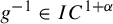 $g^{-1}\in IC^{1+\alpha }$
.
2.2.3 Dominated splitting
Let
 $\Lambda $
be a compact
 $\varphi $
-invariant set and F be a continuous
 $D\varphi $
-invariant linear fiber bundle over
 $\Lambda $
. We say that F has a dominated splitting if there exists a decomposition
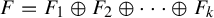 $F = F_1\oplus F_2\oplus \cdots \oplus F_k$
into continuous
 $D\varphi $
-invariant sub-bundles
 $F_1,\dots , F_k$
over
 $\Lambda $
, and there exist constants
 $C>0$
and
 $\unicode{x3bb} \in (0,1)$
such that
 $$ \begin{align*} \lVert D\varphi^n(x)|_{F_{i+1}(x)}\rVert \leq C\unicode{x3bb}^n\lVert(D\varphi^{n}(x)|_{F_i(x)})^{-1}\rVert^{-1}. \end{align*} $$
Notice that for hyperbolic sets, the tangent bundle
 $T\Lambda $
has a dominated splitting given by
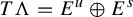 $T\Lambda = E^u\oplus E^s$
. If, additionally,
 $E^s$
has a dominated splitting of the form
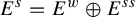 $E^s = E^w\oplus E^{ss}$
, we refer to
 $E^w$
and
 $E^{ss}$
respectively as a weak-stable and strong-stable bundle. Similar terminology is used when
 $E^u$
has a dominated splitting.
2.3 Symbolic dynamics
In this subsection, we describe subshifts of finite type. This is the class of symbolic systems that provides a combinatorial interpretation of dynamics on hyperbolic systems.
2.3.1 Subshifts of finite type
Let
 $\mathbb {A}$
be a finite set that we call an alphabet and let
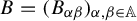 $B = (B_{\alpha \beta })_{\alpha ,\beta \in \mathbb {A}}$
be a transition matrix, that is, the entries of B satisfies
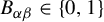 $B_{\alpha \beta } \in \{0,1\}$
for every
 $\alpha ,\beta \in \mathbb {A}$
. We say that the pair
 $(\alpha ,\beta )$
is admissible (or B-admissible) if
 $B_{\alpha \beta } = 1$
.
A finite word
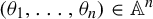 $ (\theta _1,\ldots , \theta _n)\in \mathbb {A}^n$
(or a sequence
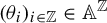 $(\theta _i)_{i\in \mathbb {Z}} \in \mathbb {A}^{\mathbb {Z}}$
) is admissible if
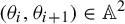 $(\theta _i,\theta _{i+1})\in \mathbb {A}^2$
is admissible for every i. Denote by
 $\Sigma $
the subset of
 $\mathbb {A}^{\mathbb {Z}}$
formed by the admissible sequences. We refer to the pair
 $(\sigma ,\, \Sigma )$
as the subshift of finite type associated to B, where
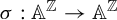 $\sigma :\mathbb {A}^{\mathbb {Z}}\to \mathbb {A}^{\mathbb {Z}}$
denotes the shift map.
Throughout this article, we only deal with transitive matrices. We say that B is a transitive matrix if for every pair
 $(\alpha ,\beta )\in \mathbb {A}^2$
, there exists
 $j\in \mathbb {N}$
such that
 $B_{\alpha \beta }^j>0$
. This condition implies the (topological) transitivity of the shift
 $\sigma :\Sigma \to \Sigma $
. In particular, for each pair of symbols
 $(\alpha , \beta )\in \mathbb {A}^2$
, there exists a finite admissible word c such that the word
 $(\alpha , c, \beta )$
is admissible (sometimes, we also write
 $\Sigma $
-admissible). We refer to such a word c as a gluing word connecting
 $\alpha $
and
 $\beta $
.
The notion of topologically mixing for a subshift of finite type
 $(\sigma ,\, \Sigma )$
can also be characterized in terms of the transition matrix B. Namely,
 $(\sigma ,\, \Sigma )$
being topologically mixing is equivalent to B being aperiodic, meaning that there is a positive integer m such that all entries of the matrix
 $B^m$
are positive.
Given a sequence
 $\theta = (\theta _n)_{n\in \mathbb {Z}}\in \mathbb {A}^{\mathbb {Z}}$
, we write
 $$ \begin{align*} \theta^-:= (\ldots, \theta_{-n},\ldots, \theta_{-1},\theta_0) \quad \text{and} \quad \theta^+ := (\theta_1,\ldots, \theta_n,\ldots). \end{align*} $$
We also write
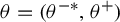 $\theta = (\theta ^{-\ast }, \theta ^+)$
, where
 $\ast $
indicates the zeroth position of the sequence
 $\theta $
, which, in this case, is placed at the symbol
 $\theta _0$
.
Given a finite word
 $a = (a_1,\ldots , a_n)\in \mathbb {A}^n$
and
 $m\in \mathbb {Z}$
, we denote by
 $$ \begin{align*} C_m(a) = \{ \theta\in \mathbb{A}^{\mathbb{Z}}\colon \theta_{m-1+i} = a_i\, \text{for all }\, 1\leq i\leq n \} \end{align*} $$
the cylinder defined by a starting at m. Similarly, we can define the cylinder associated with an infinite sequence
 $a\in \mathbb {A}^{\mathbb {N}}$
. In the case with which we are working, a subshift of finite type
 $(\Sigma , \sigma )$
and
 $a\in \mathbb {A}^n$
is a finite
 $\Sigma $
-admissible word, and
 $C_m(a)$
represents a subset of
 $\Sigma $
. Another simplification that we adhere to is dropping the word admissible once the subshift with which we are working is fixed.
For each sequence
 $\theta \in \Sigma $
, we set
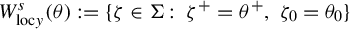 $W^s_{\mathrm {loc}y}(\theta ) := \{\zeta \in \Sigma \colon \, \zeta ^+ = \theta ^+,\, \zeta _0=\theta _0\}$
and
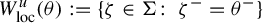 $W^u_{\mathrm {loc}}(\theta ) := \{\zeta \in \Sigma \colon \, \zeta ^- = \theta ^-\}$
. For each pair of sequences
 $\theta ,\zeta \in \Sigma $
with
 $\theta _0 = \zeta _0$
, the intersection
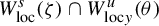 $W^s_{\mathrm {loc}}(\zeta )\cap W^u_{\mathrm {loc}y}(\theta )$
consists of a single point denoted by the brackets
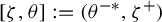 $[\zeta , \theta ] := (\theta ^{-*},\zeta ^+)$
. The symbolic unstable holonomy between two sequences
 $\theta $
and
 $\zeta $
, with
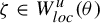 $\zeta \in W^u_{{loc}}(\theta )$
, is defined as the map
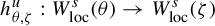 $h^u_{\theta ,\zeta }:W^s_{\mathrm {loc}}(\theta )\to W^s_{\mathrm {loc}}(\zeta )$
,
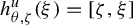 $h^u_{\theta ,\zeta }(\xi ) = [\zeta , \xi ]$
. The symbolic stable holonomy is defined similarly.
If
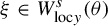 $\xi \in W^s_{\mathrm {loc}y}(\theta )$
, then
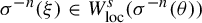 $\sigma ^{-n}(\xi )\in W^s_{\mathrm {loc}}(\sigma ^{-n}(\theta ))$
if and only if
 $\xi _{-i} = \theta _{-i}$
for every
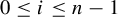 $0\leq i \leq n-1$
. Under these conditions, we have the following invariance property of the holonomies: restricted to
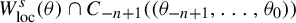 $W^s_{\mathrm {loc}}(\theta )\cap C_{-n+1}((\theta _{-n+1},\ldots , \theta _0))$
,
 $$ \begin{align} \sigma^n\circ h^u_{\sigma^{-n}(\theta),\sigma^{-n}(\zeta)}\circ \sigma^{-n} = h^u_{\theta,\zeta}. \end{align} $$
2.3.2 Markov partitions for horseshoes
Let
 $\Lambda $
be a horseshoe for a diffeomorphism
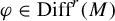 $\varphi \in \operatorname {Diff}^r(M)$
,
 $r\geq 1$
, and let
 $\delta>0$
be a small real number. A rectangle P is a subset of
 $\Lambda $
with
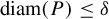 $\operatorname {diam}(P)\leq \delta $
, such that for every
 $x,y\in P$
,
 $$ \begin{align} [x,y]_{\delta} := W^s_{\delta}(x)\cap W^u_{\delta}(y) \subset P. \end{align} $$
A rectangle
 $P\subset \Lambda $
is said to be proper if
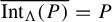 $\overline {\operatorname {Int}_{\Lambda }(P)} = P$
. A Markov partition
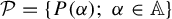 $\mathcal {P} = \{P(\alpha );\, \alpha \in \mathbb {A}\}$
for
 $\Lambda $
is a finite partition of
 $\Lambda $
by proper rectangles satisfying that for every
 $\alpha ,\beta \in \mathbb {A}$
,
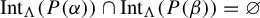 $\operatorname {Int}_{\Lambda }(P(\alpha ))\cap \operatorname {Int}_{\Lambda }(P(\beta )) = \varnothing $
and if
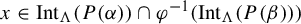 $x\in \operatorname {Int}_{\Lambda }(P(\alpha ))\cap \varphi ^{-1}(\operatorname {Int}_{\Lambda }(P(\beta )))$
, then
 $$ \begin{align*} \varphi(W^s_{\delta}(x)\cap P(\alpha))\subset W^s_{\delta}(\varphi(x))\cap P(\beta) \quad \text{and} \quad \varphi(W^u_{\delta}(x)\cap P(\alpha))\supset W^u_{\delta}(\varphi(x))\cap P(\beta). \end{align*} $$
The finite set
 $\mathbb {A}$
is an alphabet associated with the Markov partition
 $\mathcal {P}$
. The diameter of the Markov partition
 $\mathcal {P}$
is defined as the maximum of the quantities
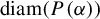 $\operatorname {diam}(P(\alpha ))$
, with
 $\alpha \in \mathbb {A}$
. By Bowen [Reference Bowen5], given a horseshoe, we can always find Markov partitions with arbitrarily small diameters.
Let
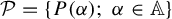 $\mathcal {P} = \{P(\alpha );\ \alpha \in \mathbb {A}\}$
be a Markov partition for the horseshoe
 $\Lambda $
. We say that a pair
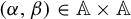 $(\alpha ,\beta )\in \mathbb {A}\times \mathbb {A}$
is admissible (or
 $\Lambda $
-admissible) if
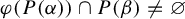 $\varphi (P(\alpha ))\cap P(\beta )\neq \varnothing $
. Set
 $$ \begin{align*} \Sigma = \{ (\theta_i)_{i\in \mathbb{Z}} \in \mathbb{A}^{\mathbb{Z}};\ (\theta_i, \theta_{i+1}) \text{ is admissible for every } i\in \mathbb{Z} \}, \end{align*} $$
and note that
 $\Sigma $
is invariant by the shift map
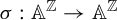 $\sigma :\mathbb {A}^{\mathbb {Z}}\to \mathbb {A}^{\mathbb {Z}}$
and by the transitivity of the horseshoe, and
 $\sigma |_{\Sigma }$
is transitive. Moreover, there exists a bi-Hölder map [Reference Katok and Hasselblatt17, Theorem 19.1.2]
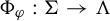 $\Phi _{\varphi }:\Sigma \rightarrow \Lambda $
conjugating the maps
 $\varphi |_{\Lambda }$
and
 $\sigma |_{\Sigma }$
, that is,
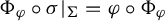 $\Phi _{\varphi }\circ \sigma |_{\Sigma } = \varphi \circ \Phi _{\varphi }$
. In this case, the transition matrix
 $B = (B_{\alpha \beta })$
is determined by the condition
 $$ \begin{align*} B_{\alpha\beta} = \begin{cases} 1 & \text{if }\operatorname{Int}\varphi(P(\alpha))\cap \operatorname{Int} P(\beta) \neq \varnothing, \\ 0 & \text{ otherwise}. \end{cases} \end{align*} $$
We can use the map
 $\Phi _{\varphi }$
to relate the dynamics of the horseshoe with its symbolic counterpart. For instance,
 $\Phi _{\varphi }$
relates the previously introduced two notions of brackets. Indeed, first observe that there exists
 $n_{\delta }$
such that for any finite word
 $a \in \mathbb {A}^{2n_{\delta }+1}$
and any
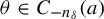 $\theta \in C_{-n_{\delta }}(a)$
, we have that the restrictions
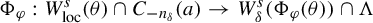 $\Phi _{\varphi }: W^s_{\mathrm {loc}}(\theta )\cap C_{-n_{\delta }}(a)\to W^s_{\delta }(\Phi _{\varphi }(\theta ))\cap \Lambda $
and
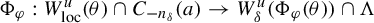 $\Phi _{\varphi }: W^u_{\mathrm {loc}}(\theta )\cap C_{-n_{\delta }}(a)\to W^u_{\delta }(\Phi _{\varphi }(\theta ))\cap \Lambda $
are well defined. So, for
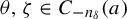 $\theta ,\zeta \in C_{-n_{\delta }}(a)$
,
 $$ \begin{align} [ \Phi_{\varphi}(\theta),\, \Phi_{\varphi}(\zeta) ]_{\delta} = \Phi_{\varphi}([ \theta,\, \zeta ]). \end{align} $$
Notice that if
 $x_0,y_0$
are in the same rectangle of the Markov partition
 $\mathcal {P}$
, say
 $\mathcal {P}(\alpha )$
, with
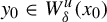 $y_0\in W^u_{\delta }(x_0)$
, we may use the brackets notation to have an explicit expression to the unstable holonomy
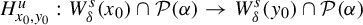 $H^u_{x_0,y_0}:W^s_{\delta }(x_0)\cap \mathcal {P}(\alpha )\to W^s_{\delta }(y_0)\cap \mathcal {P}(\alpha )$
by
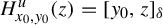 $H^u_{x_0,y_0}(z) = [y_0,z]_{\delta }$
. Analogously, we can express the stable holonomy using the brackets notation.
Take
 $x_0,y_0\in \Lambda $
with
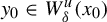 $y_0\in W^u_{\delta }(x_0)$
, and consider
 $H^u_{x_0,y_0}$
the unstable holonomy between
 $W^s_{\delta }(x_0)\cap \Lambda $
and
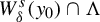 $W^s_{\delta }(y_0)\cap \Lambda $
. For any finite word
 $a \in \mathbb {A}^{2n_{\delta }+1}$
, if
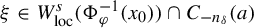 $\xi \in W^s_{\mathrm {loc}}(\Phi ^{-1}_{\varphi }(x_0))\cap C_{-n_{\delta }}(a)$
, then
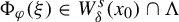 $\Phi _{\varphi }(\xi ) \in W^s_{\delta }(x_0)\cap \Lambda $
and so, by (2.3),
 $$ \begin{align} H^u_{x_0,y_0}\circ \Phi_{\varphi}(\xi) = [y_0,\, \Phi_{\varphi}(\xi)]_{\delta} = \Phi_{\varphi}([ \Phi_{\varphi}^{-1}(y_0),\, \xi ]) = \Phi_{\varphi}\circ h^u_{\Phi_{\varphi}^{-1}(x_0), \Phi^{-1}_{\varphi}(y_0)}(\xi). \end{align} $$
In particular, we can express the invariance of the holonomy in the following way: there exists a decreasing sequence of positive parameters
 $(\delta _n)_n$
,
 $\delta _0 = \delta $
, such that the restriction of
 $H^u_{x_0,y_0}$
to
 $W^s_{\delta _n}(x_0)\cap \Lambda $
satisfies
 $$ \begin{align} H^u_{x_0,y_0} = \varphi^n\circ H^u_{\varphi^{-n}(x_0),\varphi^{-n}(y_0)}\circ \varphi^{-n}. \end{align} $$
This is an immediate consequence of the symbolic holonomy invariance (2.1) and (2.4) above.
2.3.3 Symbolic towers
Let
 $\Sigma \subset \mathbb {A}^{\mathbb {Z}}$
such that
 $(\sigma ,\, \Sigma )$
is a subshift of finite type associated to a transition matrix B. For every finite set of finite B-admissible words
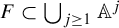 $F\subset \bigcup _{j\geq 1}\mathbb {A}^j$
, we may associate the subshift of the sequences that are produced by concatenations of words in F in the following way: consider the alphabet
 $\mathbb {A}(F):= F$
and define the transition matrix
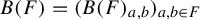 $B(F) = (B(F)_{a,b})_{a,b\in F}$
given by
 $$ \begin{align*} B(F)_{a,b} = \begin{cases} 1 & \text{if } (a,b) \text{ is } B\text{-admissible}, \\ 0 & \text{otherwise}, \end{cases} \end{align*} $$
where
 $(a,b)$
denotes the concatenation of the words a and b. Denote by
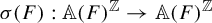 $\sigma (F):\mathbb {A}(F)^{\mathbb {Z}}\to \mathbb {A}(F)^{\mathbb {Z}}$
the shift map and by
 $\Sigma (F)$
the set of
 $B(F)$
admissible words in the alphabet
 $\mathbb {A}$
. We can see
 $\Sigma (F)$
as a subset
 $\Sigma $
. Using this identification, for every
 $a\in \mathbb {A}(F)$
, we can write
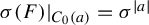 $\sigma (F)|_{C_0(a)} = \sigma ^{|a|}$
, where
 $|a|$
denotes the length of the word a. In particular, if
 $F\subset \mathbb {A}^k$
consists of B-admissible subwords of the same length in the alphabet
 $\mathbb {A}$
, then we simply write
 $\sigma (F) = \sigma ^k$
and
 $\Sigma (F) \subset \Sigma $
.
We say that
 $\Sigma $
is a tower of size
 $k\in \mathbb {N}$
over a
 $\sigma ^k$
-invariant subset
 $\Sigma _0\subset \Sigma $
if
 $\Sigma _0 = \Sigma (F)$
, where
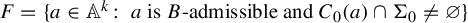 $F= \{ a\in \mathbb {A}^k\colon \, a \text { is } B\text {-admissible and } C_0(a)\cap \Sigma _0\neq \varnothing \}$
.
Example 2.1. A natural way to produce a tower over a given subshift can be described as follows. Let
 $\mathbb {A}_0$
be a finite alphabet and
 $(\sigma _0,\, \Sigma _0)$
be a subshift of finite type associated to the alphabet
 $\mathbb {A}_0$
associated to a transition matrix
 $B_0$
. Define the alphabet,
 $$ \begin{align*} \mathbb{A} := \{ (j,\, \alpha)\colon\, 0\leq j \leq k-1 \text{ and } \alpha \in \mathbb{A}_0 \}, \end{align*} $$
and transition matrix B on the alphabet
 $\mathbb {A}$
by the rule that a pair of symbols in
 $\mathbb {A}$
,
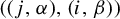 $((j,\alpha ),(i,\beta ))$
is B-admissible if
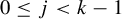 $0\leq j < k-1$
,
 $i = j + 1$
, and
 $\beta = \alpha $
or
 $j = k-1$
,
 $i = 0$
, and
 $(\alpha ,\, \beta )$
is
 $B_0$
-admissible. Let
 $(\sigma ,\, \Sigma )$
be the subshift of finite type on the alphabet
 $\mathbb {A}$
associate to B. Then, it is natural to see
 $\Sigma $
as a tower of size k for
 $\Sigma _0$
. Indeed,
 $\Sigma _0$
may be identified with
 $\Sigma (F)\subset \mathbb {A}^k$
, where
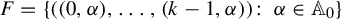 $F = \{((0,\alpha ),\ldots , (k-1,\alpha ))\colon \, \alpha \in \mathbb {A}_0\}$
, and
 $\sigma _0$
may be identified with
 $\sigma ^k$
.
Proposition 2.2. Let
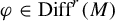 $\varphi \in \operatorname {Diff}^r(M)$
and let
 $\Lambda _0\subset M$
be a horseshoe associated to
 $\varphi ^k$
,
 $k\geq 2$
. Then, the set
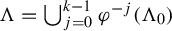 $\Lambda = \bigcup _{j=0}^{k-1}\varphi ^{-j}(\Lambda _0)$
is a horseshoe for
 $\varphi $
. Moreover, there exist an alphabet
 $\mathbb {A}$
and sets
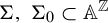 $\Sigma ,\, \Sigma _0\subset \mathbb {A}^{\mathbb {Z}}$
such that
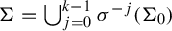 $\Sigma = \bigcup _{j=0}^{k-1}\sigma ^{-j}(\Sigma _0)$
and
 $(\sigma ,\, \Sigma )$
,
 $(\sigma ^k,\, \Sigma _0)$
are subshifts of finite type conjugated respectively to
 $(\varphi ,\, \Lambda )$
and
 $(\varphi ^k,\, \Lambda _0)$
. In particular,
 $\Sigma $
is a tower of size k over
 $\Sigma _0$
.
Proof. Consider an alphabet
 $\mathbb {A}_0$
and a subshift of finite type
 $(\sigma _0, \Sigma _0)$
, with alphabet
 $\mathbb {A}_0$
, conjugated to the horseshoe
 $(\varphi ^k,\, \Lambda _0)$
. Using the construction given in Example 2.1, we can produce a subshift of finite type
 $(\sigma ,\, \Sigma )$
such that
 $\Sigma _0$
can be seen as a
 $\sigma ^k$
-invariant subset of
 $\Sigma $
and
 $\sigma _0 = \sigma ^k$
. It is direct to check that
 $(\sigma ,\, \Sigma )$
is conjugated to
 $(\varphi ,\, \Lambda )$
and
 $\Sigma $
is a tower of size k over
 $\Sigma _0$
.
2.4 Intrinsic derivatives
Most of this article is devoted to analyzing the regularity of functions defined on compact sets. For that, we rely on a weaker version of differentiability introduced by Whitney in [Reference Whitney36]. We follow the exposition and terminology presented in [Reference Palis and Viana28].
Let X be a compact subset of
 $\mathbb {R}^m$
. We say that a function
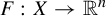 $F:X\to \mathbb {R}^n$
is intrinsically differentiable (or shorter,
 $IC^1$
) if there exists a continuous map
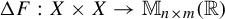 $\Delta F: X\times X\to \mathbb {M}_{n\times m}(\mathbb {R})$
such that for every
 $x,y\in X$
,
 $$ \begin{align*} F(x) - F(y) = \Delta F(x,y)\, (x-y). \end{align*} $$
If additionally the map
 $\Delta F$
is
 $\gamma $
-Hölder continuous for some
 $\gamma \in (0,1]$
, we say that F is
 $IC^{1+\gamma }$
and write
 $F\in IC^{1+\alpha }$
. It is important to point out that, unlike classical derivatives, the intrinsic derivative, when it exists, does not need to be unique.
Classical derivatives and intrinsic derivatives share many basic properties. The reason for that is the fact that intrinsic differentiable functions on compact sets are restrictions of classical differentiable functions defined on slightly bigger open sets. See [Reference Whitney36] (see [Reference Palis and Viana28, §2] for the precise statements and proofs of the basic properties used in this work without further reference).
For a compact set
 $X\subset \mathbb {R}^m$
, we also define the intrinsic tangent space of X at a point
 $x\in X$
,
 $IT_xX$
, as the span of the directions
 $v\in \mathbb {R}^m$
, such there exists a compact set
 $K(v)\subset \mathbb {R}$
,
 $0\in K(v)$
, and an
 $IC^1$
map
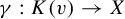 $\gamma :K(v)\to X$
such that
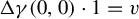 $\Delta \gamma (0,0)\cdot 1 = v$
. Another characterization of the tangent space that does not refer to curves is the following:
 $$ \begin{align*} IT_xX = \text{span}\bigg\{ \frac{x_n-y_n}{\lVert x_n - y_n\rVert}\colon\, x_n,y_n\in X, x_n,y_n\to x \bigg\}. \end{align*} $$
Notice that if
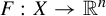 $F:X\to \mathbb {R}^n$
is
 $IC^1$
, then for every
 $z\in X$
, the intrinsic derivative
 $\Delta F(z,z)$
sends
 $IT_zX$
into
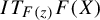 $IT_{F(z)}F(X)$
.
2.5 Linearization
In this section, we elaborate on how to locally linearize all maps on an open set of smooth diffeomorphisms. Its content is not essential for obtaining the main results in this article. However, the linearization technique discussed here may be of independent interest and can serve as a reference for future work.
Given
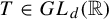 $T\in GL_d(\mathbb {R})$
a hyperbolic matrix of saddle-type, that is,
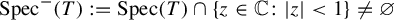 $\operatorname {Spec}^-(T) := \operatorname {Spec}(T)\cap \{z\in \mathbb {C}\colon |z|<1\} \neq \varnothing $
and
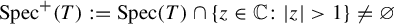 $\operatorname {Spec}^+(T) := \operatorname {Spec}(T)\cap \{z\in \mathbb {C}\colon |z|>1\} \neq \varnothing $
, we define the spectral spreading of T by the quantities
 $$ \begin{align*} \rho^{\pm}(T) := \frac{ \operatorname\max\{ \lvert\log\rvert\unicode{x3bb}||\colon\, \unicode{x3bb} \in \operatorname{Spec}^{\pm}(T) \} }{ \operatorname\min\{ \lvert\log\rvert\unicode{x3bb}||\colon\, \unicode{x3bb} \in \operatorname{Spec}^{\pm}(T) \} }. \end{align*} $$
Given a natural number
 $r\geq 1$
, we define the r-smoothness of T by
 $$ \begin{align*} K^r(T) := \bigg\lfloor \kern-4pt\operatorname\max_{m,n\in \mathbb{N}\colon\, m+n = r} \operatorname\min\bigg\{ \frac{m}{\rho^+(T)}, \frac{n}{\rho^-(T)} \bigg\} \kern-3pt\bigg\rfloor. \end{align*} $$
Let
 $\unicode{x3bb} _1,\ldots , \unicode{x3bb} _d$
be the eigenvalues of T counted with multiplicity and consider the function
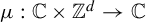 $\mu :\mathbb {C}\times \mathbb {Z}^d\to \mathbb {C}$
given by
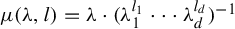 $\mu (\unicode{x3bb} , l) = \unicode{x3bb} \cdot (\unicode{x3bb} _1^{l_1}\cdots \unicode{x3bb} _d^{l_d})^{-1}$
. We say that T satisfies the resonant condition of order r if
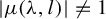 $|\mu (\unicode{x3bb} , l)| \neq 1$
for every
 $l\in \mathbb {Z}^d$
with
 $2\leq |l| \leq r$
and for every
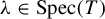 $\unicode{x3bb} \in \operatorname {Spec}(T)$
.
Proposition 2.3. One has that:
-
(1) the maps
$T\mapsto \rho ^+(T)$
and
$T\mapsto \rho ^-(T)$
are continuous; -
(2) the set of matrices satisfying the resonant condition of order r is open and dense on
$GL_d(\mathbb {R})$
.
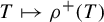
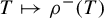

Proof. The proof of the proposition follows directly from the continuity of the eigenvalues when varying the matrix. For item (2), notice that the resonant condition of order r imposes at most a finite number of constraints in the set of eigenvalues.
Let
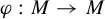 $\varphi :M\to M$
be a
 $C^r$
-diffeomorphism,
 $r\geq 1$
, and consider
 $p\in M$
a hyperbolic periodic point of saddle-type. We write
 $\rho ^{\pm }_p(\varphi )$
and
 $K_{p}^r(\varphi )$
to denote respectively
 $\rho ^{\pm }(D\varphi ^{\operatorname {Per}(p)}(p))$
and
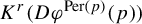 $K^r(D\varphi ^{\operatorname {Per}(p)}(p))$
. We also say that
 $(\varphi , p)$
satisfies the resonant condition of order r if
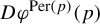 $D\varphi ^{\operatorname {Per}(p)}(p)$
satisfies the resonant condition of order r.
The diffeomorphism
 $\varphi $
admits a k-linearization around p if there exists a
 $C^k$
-chart
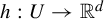 $h:U\to \mathbb {R}^d$
centered at p, such that
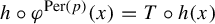 $h \circ \varphi ^{\operatorname {Per}(p)}(x) = T \circ h(x)$
for every
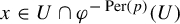 $x \in U \cap \varphi ^{-\operatorname {Per}(p)}(U)$
, where T is the expression of
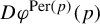 $D\varphi ^{\operatorname {Per}(p)}(p)$
in this system of coordinates. The next result gives conditions for
 $C^k$
-linearization in terms of
 $K_p^r(\varphi )$
.
Theorem 2.4. (Sell [Reference Sell34])
Let
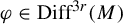 $\varphi \in \operatorname {Diff}^{3r}(M)$
,
 $r\geq 2$
, admitting a hyperbolic periodic point of saddle-type p. Assume that
 $(\varphi , p)$
satisfies the resonant condition of order r. Then,
 $\varphi $
admits a
 $K^r_p(\varphi )$
-linearization around p.
For any
 $1\leq r \leq \infty $
, let
 $\mathcal {H}^r(M)$
be the set of diffeomorphisms
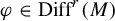 $\varphi \in \operatorname {Diff}^r(M)$
admitting a hyperbolic periodic point of saddle-type. Consider
 $\varphi \in \mathcal {H}^r(M)$
and let
 $p\in M$
be such a hyperbolic periodic point. Define
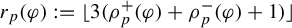 $r_p(\varphi ) := \lfloor 3(\rho ^+_p(\varphi )+\rho ^-_p(\varphi ) + 1)\rfloor $
. We also define the subset
 $\mathcal {L}^r(M)$
of
 $\mathcal {H}^r(M)$
of diffeomorphisms
 $\varphi $
admitting a hyperbolic periodic point of saddle-type
 $p\in M$
such that:
-
(i)
$(\varphi , p)$
satisfies the resonant condition of order
$r_p(\varphi )$
; -
(ii)
$r_p(\varphi ) < r/3$
.


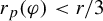
Proposition 2.5. Assume
 $r\geq 6$
.
-
(1) If
$\varphi \in \mathcal {L}^r(M)$
and
$p\in M$
is a periodic point of
$\varphi $
satisfying conditions (i) and (ii), then
$\varphi $
admits a
$3$
-linearization around p. -
(2) The set
$\mathcal {L}^r(M)$
is
$C^1$
-open in
$\operatorname {Diff}^r(M)$
and
$C^r$
-dense on the set of
$\varphi \in \mathcal {H}^r(M)$
admitting a hyperbolic periodic point of saddle-type
$p\in M$
with
$r_p(\varphi )< r/3$
. In particular,
$\mathcal {L}^{\infty }(M)$
is
$C^1$
-open and
$C^{\infty }$
-dense in
$\mathcal {H}^{\infty }(M)$
.


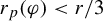


Proof. To see item (1), notice that we can apply Theorem 2.4 with the regularity
 $r':=r_p(\varphi )$
. Indeed, since
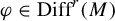 $\varphi \in \operatorname {Diff}^r(M)$
,
 $r\geq 6$
, condition (ii) guarantees that
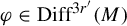 $\varphi \in \operatorname {Diff}^{3r'}(M)$
with
 $r'\geq 2$
. Furthermore, condition (i) guarantees that
 $(\varphi , p)$
satisfies the resonant condition of order
 $r'$
. Therefore,
 $\varphi $
admits a
 $K^{r'}_p(\varphi )$
-linearization around p. However, by the definition of
 $r_p(\varphi )$
, we see that
 $K^{r'}_p(\varphi ) \geq 3$
.
Now, to see that
 $\mathcal {L}^r(M)$
is open in
 $\mathcal {H}^r(M)$
, take
 $\varphi \in \mathcal {L}^r(M)$
with p satisfying conditions (i) and (ii). By item (2) of Proposition 2.3, we can consider an open neighborhood
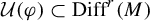 $\mathcal {U}(\varphi )\subset \operatorname {Diff}^r(M)$
of
 $\varphi $
, such that any
 $\tilde {\varphi }\in \mathcal {U}(\varphi )$
has a periodic point
 $\tilde {p}$
which is the hyperbolic continuation of p and
 $(\tilde {\varphi },\tilde {p})$
satisfies the resonant condition of order
 $r_p(\varphi )$
. Additionally, we claim that, up to decreasing the size of the neighborhood
 $\mathcal {U}(\varphi )$
, we have that for every
 $\tilde {\varphi }\in \mathcal {U}_p(\varphi )$
,
 $$ \begin{align} r_p(\varphi) - 1 \leq r_p(\tilde{\varphi}) \leq r_p(\varphi). \end{align} $$
To see this, consider the continuous map
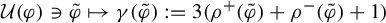 $\mathcal {U}(\varphi )\ni \tilde {\varphi }\mapsto \gamma (\tilde {\varphi }) := 3(\rho ^+(\tilde {\varphi }) + \rho ^-(\tilde {\varphi }) + 1)$
. Up to decreasing the size of
 $\mathcal {U}(\varphi )$
, we can assume that for every
 $\tilde {\varphi }\in \mathcal {U}(\varphi )$
,
 $$ \begin{align*} |\gamma(\tilde{\varphi}) - \gamma(\varphi)|\leq \begin{cases} \frac{1}{2}\operatorname\min_{m\in\mathbb{Z}}|\gamma(\varphi) - m| & \text{if } \gamma(\varphi)\notin \mathbb{Z},\\ \frac{1}{2} & \text{if }\gamma(\varphi)\in \mathbb{Z}. \end{cases} \end{align*} $$
Hence, for any
 $\tilde {\varphi }\in \mathcal {U}(\varphi )$
,
 $$ \begin{align*} r_p(\varphi) - 1 = \lfloor\gamma(\varphi)\rfloor - 1 \leq \lfloor\gamma(\tilde{\varphi})\rfloor = r_p(\tilde{\varphi}) \leq \lfloor\gamma(\varphi)\rfloor = r_p(\varphi). \end{align*} $$
Thus, for every
 $\tilde {\varphi }\in \mathcal {U}(\varphi )$
, we have
 $(\tilde {\varphi },\tilde {p})$
satisfies the resonant condition of order
 $r_{\tilde {p}}(\tilde {\varphi })$
and
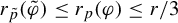 $r_{\tilde {p}}(\tilde {\varphi })\leq r_p(\varphi ) \leq r/3$
guaranteeing that
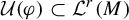 $\mathcal {U}(\varphi )\subset \mathcal {L}^r(M)$
.
For the density, consider
 $\varphi \in \mathcal {H}^r(M)$
with an hyperbolic periodic point of saddle-type satisfying
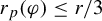 $r_p(\varphi ) \leq r/3$
. Using again item (2) of Proposition 2.3, we can find
 $\tilde {\varphi }$
,
 $C^r$
-close to
 $\varphi $
, such that if
 $\tilde {p}\in M$
is the hyperbolic continuation of p for
 $\tilde {\varphi }$
, then
 $(\tilde {\varphi }, \tilde {p})$
satisfies the resonant condition of order
 $r_p(\varphi )$
.
Furthermore, we can assume that
 $r_{\tilde {p}}(\tilde {\varphi })$
satisfies the inequality (2.6) and is such that condition (i) is valid. Also, it follows directly by inequality (2.6) that
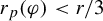 $r_p(\varphi )<r/3$
is a
 $C^1$
-open condition and so for
 $\tilde {\varphi }$
close enough to
 $\varphi $
, we have that condition (ii) is immediate. Therefore,
 $\tilde {\varphi }\in \mathcal {L}^r(M)$
. This finishes the proof of item (2) of the proposition.
3 Lagrange spectrum for symbolic dynamics
Let
 $(\sigma ,\, \Sigma )$
be a subshift of finite type associated with a transition matrix B and
 $g:\Sigma \to \mathbb {R}$
be a continuous function. The purpose of this section is to give sufficient conditions on the function g to guarantee that the Lagrange spectrum of the data
 $(\sigma ,\, g)$
contains a ‘significant’ portion of the image
 $g(\Sigma )$
. The idea is to determine the properties on the function g, ensuring that the set
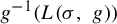 $g^{-1}(L(\sigma ,\, g))$
has a non-empty interior inside of some subshift of finite type. We follow the lines presented in [Reference Romaña Ibarra and de A. Moreira33, §4]; however, thinking of possible future applications, in this work, we provide a purely combinatorial approach to the subject.
In what follows, we keep the same notation as in §2.3. Given a set of finite words
 $\mathcal {W}$
, we define the subset of
 $\Sigma $
,
 $\Sigma (\mathcal {W}^c)$
, of sequences which never enter, through shift action, into the cylinders determined by the words in
 $\mathcal {W}$
. In other words,
 $$ \begin{align*} \Sigma({\mathcal{W}}^c) := \{ \theta\in \Sigma \colon\, \sigma^n(\theta) \notin C_0(b) \text{ for all } b\in \mathcal{W},\, n\in \mathbb{Z} \}. \end{align*} $$
We are interested in the subset of sequences that are defined by exclusion of subwords of a given finite sequence
 $a\in \mathbb {A}^{2n+1}$
. More precisely,
 $$ \begin{align*} \mathcal{W}_{1/3}(a) := \bigg\{ b\in \bigcup_{j=1}^{|a|}\mathbb{A}^j \colon\, |b| \geq \lfloor |a|/3 \rfloor \text{ and} \text{ there exists }\, j\in \mathbb{Z} \text{ with } C_j(a) \subset C_0(b) \bigg\}. \end{align*} $$
Define
 $$ \begin{align*} \Sigma_{1/3}(a^c) := \Sigma(\mathcal{W}_{1/3}(a)^c). \end{align*} $$
It is reasonable to expect that if
 $(\Sigma ,\sigma )$
is topologically mixing, then removing a word
 $a\in \mathbb {A}^{2n+1}$
of sufficiently large length (small diameter cylinder) from the alphabet has little effect in the way we connect the symbols in
 $\mathcal {W}_{1/3}(a)$
. The following proposition formalizes this reasoning.
Proposition 3.1. Let
 $(\sigma ,\, \Sigma )$
be a mixing subshift of finite type. Then, there is an
 $n_0\in \mathbb {N}$
such that for every
 $n\geq n_0$
and every admissible word
 $a\in \mathbb {A}^{2n+1}$
,
 $(\sigma ,\, \Sigma _{1/3}(a^c))$
is a transitive subshift of finite type.
Proof. Let B be the aperiodic transitive matrix associated to
 $\Sigma $
. Consider
 $m\in \mathbb {N}$
such that
 $B^m_{\alpha \beta }>0$
for every
 $\alpha , \beta \in \mathbb {A}$
. Write
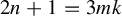 $2n+1 = 3mk$
, with the value of k to be chosen later sufficiently large. So, given
 $a\in \mathbb {A}^{2n+1}$
admissible, any word
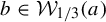 $b\in \mathcal {W}_{1/3}(a)$
is a subword of a with length at least
 $mk$
.
To prove that
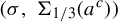 $(\sigma ,\, \Sigma _{1/3}(a^c))$
is transitive, it is enough to check that any pair of admissible words
 $e,f\in \mathbb {A}^{mk}$
, which are not in
 $\mathcal {W}_{1/3}(a)$
, can be connected by concatenating words outside of
 $\mathcal {W}_{1/3}(a)$
. For that, fix
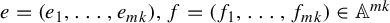 $e = (e_1,\ldots , e_{mk}), f = (f_1,\ldots , f_{mk})\in \mathbb {A}^{mk}$
.
From the fact that
 $(\sigma ,\Sigma )$
is topologically mixing, for each finite word
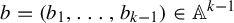 $b = (b_1,\ldots , b_{k-1})\in \mathbb {A}^{k-1}$
, we can construct a gluing word
 $c(b)$
connecting
 $e_{mk}$
to f of the form
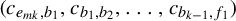 $(c_{e_{mk},b_1}, c_{b_1,b_2},\ldots , c_{b_{k-1}, f_1})$
of length
 $mk$
. Here,
 $c_{\alpha ,\beta }$
denotes a gluing word connecting the symbol
 $\alpha $
to the symbol
 $\beta $
of length m—this is justified by the mixing assumption. Hence, the injectivity of the map
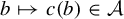 $b\mapsto c(b)\in \mathcal {A}$
ensures that
 $$ \begin{align*} B^{mk}_{e_{mk},f_1} \geq ( \# \mathbb{A} )^{k-1}. \end{align*} $$
Since for k sufficiently large
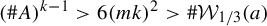 $(\# A)^{k-1}> 6(mk)^2 > \# \mathcal {W}_{1/3}(a)$
, we see that there exists an admissible connection (a gluing word of length
 $mk$
) in
 $\Sigma _{1/3}(a^c)$
between the words e and f.
Proposition 3.2. Let
 $(\sigma ,\, \Sigma )$
be a tower of size k over a mixing subshift of finite type
 $(\sigma ^k,\Sigma _0)$
with
 $\Sigma _0\subset \Sigma $
. Then, there exists
 $n_0\in \mathbb {N}$
such that for every
 $n\geq n_0$
and every admissible word
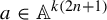 $a\in \mathbb {A}^{k(2n+1)}$
,
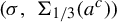 $(\sigma ,\, \Sigma _{1/3}(a^c))$
is a transitive subshift of finite type.
Proof. Let
 $\mathbb {A}_0\subset \mathbb {A}^k$
with
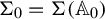 $\Sigma _0 = \Sigma (\mathbb {A}_0)$
(see the notation introduced in §2.3.3). Since
 $(\sigma ^k,\, \Sigma _0)$
is topologically mixing, by Proposition 3.1, there exists
 $n_0\in \mathbb {N}$
such that for every
 $n\geq n_0$
and every word
 $b\in \mathbb {A}_0^{2n+1}$
,
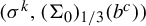 $(\sigma ^k, (\Sigma _0)_{1/3}(b^c))$
is a transitive subshift of finite type.
Given
 $n\geq n_0$
and a
 $\Sigma $
-admissible word
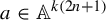 $a\in \mathbb {A}^{k(2n+1)}$
, we can associate a
 $\Sigma _0$
-admissible word
 $b \in \mathbb {A}_0^{2n+1}$
such that for every
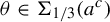 $\theta \in \Sigma _{1/3}(a^c)$
, there exists
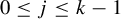 $0\leq j \leq k-1$
with
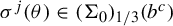 $\sigma ^j(\theta )\in (\Sigma _0)_{1/3}(b^c)$
. In other words, we can write
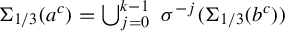 $\Sigma _{1/3}(a^c) = \bigcup _{j=0}^{k-1}\, \sigma ^{-j}(\Sigma _{1/3}(b^c))$
. In particular,
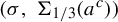 $(\sigma ,\, \Sigma _{1/3}(a^c))$
is transitive.
For each pair
 $(\alpha , \beta )\in \mathbb {A}^2$
, fix a gluing word
 $c_{\alpha ,\beta }$
connecting
 $\alpha $
and
 $\beta $
with minimal length. Let
 $a = (a_{-n},\ldots , a_0,\ldots , a_n)\in \mathbb {A}^{2n + 1}$
be a finite admissible word and define the map
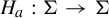 $H_a:\Sigma \to \Sigma $
given by
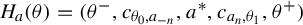 $H_a(\theta ) = (\theta ^-,c_{\theta _0,a_{-n}}, a^*, c_{a_{n}, \theta _1}, \theta ^+)$
. More explicitly,
 $$ \begin{align*} H_a(\theta) := (\ldots \theta_{-2}, \theta_{-1}, \theta_0, c_{\theta_0,a_{-n}}, a_{-n}, \ldots, a_0^*, \ldots, a_{n}, c_{a_{n}, \theta_1}, \theta_1, \theta_2, \ldots). \end{align*} $$
The following proposition expresses
 $H_a$
dynamically in terms of the holonomy maps.
Proposition 3.3. For each
 $d\in \mathbb {A}^2 \Sigma $
-admissible, there exists
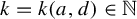 $k = k(a,d)\in \mathbb {N}$
such that for every
 $\xi \in C_0(d)$
and every
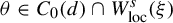 $\theta \in C_0(d)\cap W^s_{\mathrm {loc}}(\xi )$
,
 $$ \begin{align*} H_a(\theta) = \sigma^k \circ h^u_{\xi, \sigma^{-k} \circ H_a(\xi)}(\theta). \end{align*} $$
Proof. Let
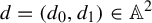 $d = (d_0,d_1)\in \mathbb {A}^2$
be a finite word and observe that for every
 $\theta \in C_0(d)$
, we can take
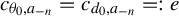 $c_{\theta _0,a_{-n}} = c_{d_0,a_{-n}} =:e$
and
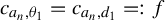 $c_{a_{n},\theta _1} = c_{a_{n}, d_1} =: f$
, and so for every
 $\theta \in C_0(d)$
,
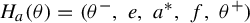 $H_a(\theta ) = (\theta ^-,\, e,\, a^*,\, f,\, \theta ^+)$
. Now, fix
 $\xi \in C_0(d)$
and take
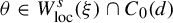 $\theta \in W^s_{\mathrm {loc}}(\xi )\cap C_0(d)$
, that is, the sequence
 $\theta $
satisfies that
 $\xi _0 = \theta _0$
and
 $\xi ^+ = \theta ^+$
. Then, taking
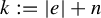 $k := |e| + n$
and
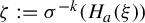 $\zeta := \sigma ^{-k}(H_a(\xi ))$
, we have
 $$ \begin{align*} \sigma^{k}\circ h^u_{\xi, \zeta}(\theta) = \sigma^{k}(\theta^{-*},\zeta^+) = \sigma^{k}(\theta^{-*}, e, a, f,\xi^+) = \sigma^{k}(\theta^{-*}, e, a, f, \theta^+) = H_a(\theta). \end{align*} $$
The following proposition is the main combinatorial result of this work and it will be essential to prove the main results.
Proposition 3.4. Let
 $g: \Sigma \to \mathbb {R}$
be a continuous function satisfying that
 $$ \begin{align} \sup_{\theta \in \Sigma\backslash C_{-n}(a)} g(\theta) < \inf_{\theta \in C_{-n}(a)} g(\theta) \end{align} $$
for some admissible word
 $a\in \mathbb {A}^{2n+1}$
with
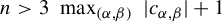 $n> 3\, \displaystyle \operatorname \max _{(\alpha ,\beta )}\, |c_{\alpha ,\beta }| + 1$
. Then, there is an open set
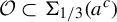 $\mathcal {O} \subset \Sigma _{1/3}(a^c)$
and
 $j_0 \in \mathbb {N}$
such that
 $$ \begin{align*} \sigma^{j_0}\circ H_a(\mathcal{O})\subset C_{-n}(a) \quad \text{and} \quad g\circ\sigma^{j_0}\circ H_a(\mathcal{O})\subset L(\sigma, g). \end{align*} $$
Proof. Write
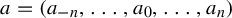 $a = (a_{-n},\ldots , a_0,\ldots , a_n)$
and
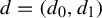 $d = (d_0,d_1)$
such that
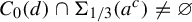 $C_0(d)\cap \Sigma _{1/3} (a^c) \neq \varnothing $
. Also, denote by
 $e, f$
the gluing words
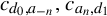 $c_{d_0,a_{-n}}, c_{a_{n}, d_1}$
of length l and m, respectively. We define the auxiliary map
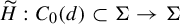 $\widetilde {H}: C_0(d) \subset \Sigma \to \Sigma $
given by
 $$ \begin{align*} \widetilde{H}(\theta)= (\ldots \theta_{-2}, \theta_{-1}, \theta_0, \tau_0^*, c_1, \tau_1, c_2, \ldots, c_k, \tau_k, c_{k+1}, \ldots), \end{align*} $$
where
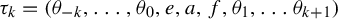 $\tau _k = (\theta _{-k}, \ldots , \theta _0, e, a, f, \theta _1, \ldots \theta _{k+1})$
, the
 $*$
indicates the zeroth position of
 $\widetilde {H}(\theta )$
located in
 $a_0$
which is the center of a inside
 $\tau _0$
and
 $c_k = c_{\theta _k, \theta _{-k}}$
,
 $k\geq 1$
. Observe that both
 $\tau _{k-1}$
and
 $c_k$
depend on
 $\theta $
for every
 $k \geq 1$
.
Let
 $l(k)$
be the position in
 $\widetilde {H}(\theta )$
of the center
 $a_0$
in a which is located in the center of
 $\tau _k$
and notice that for every
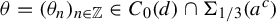 $\theta = (\theta _n)_{n\in \mathbb {Z}}\in C_0(d)\cap \Sigma _{1/3}(a^c)$
,
 $$ \begin{align} [\sigma^{n + m}(\sigma^{l(k)}\circ \tilde{H}(\theta))]^+ &= (\theta_1, \theta_2, \ldots, \theta_{k+1}, c_{k+1}, \theta_{-k-1},\ldots) \quad \text{and}\nonumber\\ [\sigma^{- (n + l)}(\sigma^{l(k)}\circ\tilde{H}(\theta))]^- &= (\ldots, \theta_k, c_k, \theta_{-k}, \ldots, \theta_{-1}, \theta_0). \end{align} $$
In particular, if
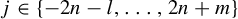 $j\in \{-2n - l,\ldots , 2n + m\}$
, we have that
 $$ \begin{align} \lim_{k\to\infty}\sigma^j(\sigma^{l(k)}\circ \tilde{H}(\theta)) = \sigma^j\circ H_a(\theta). \end{align} $$
Take
 $k> 4n$
and consider the following intervals of integers numbers:
 $$ \begin{align*} I_k^- := - (n + l) + [-k ,\, -n - 1] \quad \text{and} \quad I_k^+ := (n + m) + [n + 1,\, k+1 + |c_{k+1}|]. \end{align*} $$
Also, write
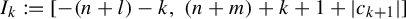 $I_k := [-(n + l) - k,\, (n + m) + k + 1 + |c_{k+1}|]$
, and notice that
 $I_k^{\pm }\subset I_k$
and
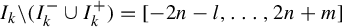 $I_k\backslash (I_k^-\cup I_k^+) = [-2n - l, \ldots , 2n + m]$
, which is independent of k, see Figure 1.
Interval of integers
 $I_n$
.

Moreover, we may decompose
 $\mathbb {N}$
as the disjoint union
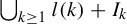 $\bigcup _{k\geq 1} l(k) + I_k$
and so,
 $$ \begin{align} \limsup_{j\to\infty} g(\sigma^j\circ\tilde{H}(\theta)) = \limsup_{k\to\infty}\sup_{j\in I_k}\, g(\sigma^{j+l(k)}(\tilde{H}(\theta))). \end{align} $$
Take
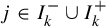 $j\in I_k^-\cup I_k^+$
. Directly from the expressions in (3.2), we can see that the interval of length
 $2n$
around the zeroth position of the sequence
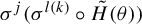 $\sigma ^j(\sigma ^{l(k)}\circ \tilde {H}(\theta ))$
shares a sub-word of length at least
 $\lfloor |a|/3 \rfloor $
with the word
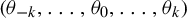 $(\theta _{-k},\ldots , \theta _0,\ldots , \theta _k)$
. Here, we are using the assumption
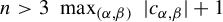 $n> 3\, \operatorname \max _{(\alpha ,\beta )}\, |c_{\alpha ,\beta }| + 1$
. Since
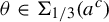 $\theta \in \Sigma _{1/3}(a^c)$
, this implies that
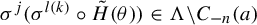 $\sigma ^j(\sigma ^{l(k)}\circ \tilde {H}(\theta )) \in \Lambda \backslash C_{-n}(a)$
. Thus, by assumption in (3.1),
 $$ \begin{align*} \sup_{j\in I_k^-\cup I_k^+}\, g(\sigma^j(\sigma^{l(k)}\circ\tilde{H}(\theta))) < g(\sigma^{l(k)}\circ \tilde{H}(\theta)), \end{align*} $$
which implies that
 $$ \begin{align} \sup_{j\in I_k}\, g(\sigma^j(\sigma^{l(k)}\circ\tilde{H}(\theta))) = \operatorname\max_{j\in I_k\backslash (I_k^-\cup I_k^+)}\, g(\sigma^{j + l(k)}\circ\tilde{H}(\theta)). \end{align} $$
Therefore, by (3.4) and (3.5), there exists
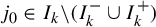 $j_0\in I_k\backslash (I_k^-\cup I_k^+)$
and a subsequence
 $k_i\to \infty $
such that
 $$ \begin{align} \limsup_{i\to\infty} g(\sigma^i\circ \tilde{H}(\theta)) = \lim_{k\to\infty} g(\sigma^{j_0 + l(k_i)}\circ \tilde{H}(\theta)) = g( \sigma^{j_0}\circ H_a(\theta)), \end{align} $$
where the last equality is justified using (3.3). For each
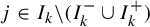 $j\in I_k\backslash (I_k^-\cup I_k^+)$
, consider the compact set
 $$ \begin{align*} \Sigma_j = \Big\{ \theta \in \Sigma_{1/3}(a^c)\cap C_0(d)\colon\! \limsup_{k\to\infty} g(\sigma^k\circ \tilde{H}(\theta)) = g( \sigma^{j}\circ H_a(\theta)) \Big\}. \end{align*} $$
Observe that for every
 $\theta \in \Sigma _j$
,
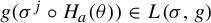 $g(\sigma ^j\circ H_a(\theta ))\in L(\sigma , g)$
. By (3.6), we see that
 $$ \begin{align*} \Sigma_{1/3}(a^c) \cap C_0(d) = \bigcup_{j\in I_k\backslash(I_k^-\cup I_k^+)}\, \Sigma_j. \end{align*} $$
Then, by Baire’s theorem, there exists
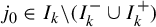 $j_0\in I_k\backslash (I_k^-\cup I_k^+)$
such that
 $\Sigma _{j_0}$
has non-empty interior. So, there exists open set
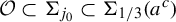 $\mathcal {O}\subset \Sigma _{j_0}\subset \Sigma _{1/3}(a^c)$
such that
 $$ \begin{align*} g\circ\sigma^{j_0}\circ H_a(\mathcal{O})\subset L(\sigma,\, g). \end{align*} $$
Finally, by definition of
 $\tilde {H}$
, we have
 $\sigma ^k(\tilde {H}(\theta ))$
belongs to
 $C_{-n}(a)$
for infinitely many
 $k>0$
. Thus, by (3.1), for every
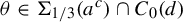 $\theta \in \Sigma _{1/3}(a^c)\cap C_0(d)$
,
 $$ \begin{align*} \displaystyle\limsup_{k\to\infty} g(\sigma^k({\tilde{H}}(\theta)))> \sup_{\zeta\in \Lambda\backslash C_{-n}(a)} g(\zeta). \end{align*} $$
However, for every
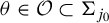 $\theta \in \mathcal {O}\subset \Sigma _{j_0}$
,
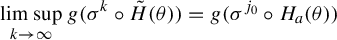 $\displaystyle \limsup _{k\to \infty } g(\sigma ^k\circ \tilde {H}(\theta )) = g( \sigma ^{j_0}\circ H_a(\theta ))$
, which implies that
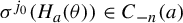 $\sigma ^{j_0}(H_a(\theta ))\in C_{-n}(a)$
.
4 Choice of the data set
In this section, we describe how to obtain the generic data set that will be used in the proof of Theorem C. The goal of the first part is to exhibit conditions ensuring the existence of horseshoes admitting stable/unstable sets with a regular Cantor set structure. The chosen conditions guarantee the regularity of the holonomies, which cannot be taken for granted in the higher dimensional setting we are examining. We will complete our data set by shifting our focus to constructing a collection of
 $C^1$
real functions that will be used in the data set to obtain a large Lagrange spectrum.
4.1 Choice of the horseshoe
Let
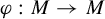 $\varphi : M\to M$
be a
 $C^r$
-diffeomorphism with
 $r\geq 1$
. Consider a hyperbolic periodic point
 $p\in M$
, and denote the stable and unstable spaces of p by
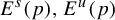 $E^s(p), E^u(p)$
, respectively. We write
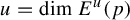 $u = \operatorname {dim} E^u(p)$
and
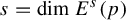 $s = \operatorname {dim} E^s(p)$
,
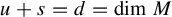 $u+s = d = \operatorname {dim} M$
. Additionally, assume that p admits a transversal homoclinic intersection in a point
 $q_0$
, meaning that the stable and unstable manifold of p intersect each other transversely at
 $q_0\in M$
. For simplicity, assume that p is a fixed point of
 $\varphi $
.
Now, we list conditions on the diffeomorphism
 $\varphi $
ensuring the existence of a horseshoe with intrinsic differentiable unstable holonomies.
Condition C1
The fixed point p has real and simple spectrum, that is, the eigenvalues of
 $D\varphi (p)$
are real with distinct absolute values.
Write the spectrum of
 $D\varphi (p)$
as
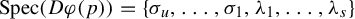 $\operatorname {Spec}(D\varphi (p)) = \{\sigma _u,\ldots ,\sigma _1,\unicode{x3bb} _1,\ldots ,\unicode{x3bb} _s\}$
, where
 $\sigma _j, \unicode{x3bb} _i \in \mathbb {R}$
,
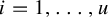 $i=1,\ldots , u$
,
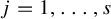 $j=1,\ldots , s$
, satisfies
 $$ \begin{align*} |\sigma_u|> |\sigma_{u-1}|>\cdots > |\sigma_1| > 1 > |\unicode{x3bb}_1|>|\unicode{x3bb}_2| > \cdots > |\unicode{x3bb}_s|. \end{align*} $$
Consider the decomposition of
 $E^s(p)$
into
 $D\varphi $
-invariant subspaces
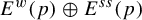 $E^w(p)\oplus E^{ss}(p)$
, where
 $E^{w}(p)$
is the one-dimensional eigenspace associated with the weakest contracting eigenvalue
 $\unicode{x3bb} _1$
and
 $E^{ss}(p)$
is the eigenspace associated with the strongest contracting eigenvalues
 $\unicode{x3bb} _2,\ldots , \unicode{x3bb} _s$
. The spaces
 $E^{w}(p)$
and
 $E^{ss}(p)$
are called respectively the weak stable and the strong stable space associated with the point fixed p.
By the strong stable manifold theorem [Reference Shub35], there exists a
 $\varphi $
-invariant submanifold of the stable manifold of p, tangent to
 $E^{ss}(p)$
. This submanifold, denoted by
 $W^{ss}(p)$
, is called strong stable manifold at p.
Condition C2
The intersection point
 $q_0$
does not belong to
 $W^{ss}(p)$
.
Remark 4.1. In the case that
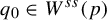 $q_0\in W^{ss}(p)$
, we cannot expect in general a good regularity of the unstable lamination. Indeed, there are simple examples of diffeomorphisms
 $\varphi $
with such properties for which the unstable holonomies are not even Lipschitz. See [Reference Palis and Viana28, Example 3.1].
Condition C3
Assume that
 $\varphi $
is linear around p. More specifically, there are
 $C^3$
-coordinates in a neighborhood
 $U_0$
of p, say
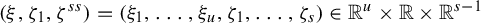 $(\xi , \zeta _1, \zeta ^{ss}) = (\xi _1,\ldots ,\xi _u,\zeta _1,\ldots ,\zeta _s)\in \mathbb {R}^u\times \mathbb {R}\times \mathbb {R}^{s-1}$
, such that:
-
(1)
$E^u(p) = [\zeta =0]$
,
$E^s(p) = [\xi = 0]$
,
$E^w(p) = [\xi = \zeta ^{ss} = 0]$
, and
$E^{ss} = [\xi = \zeta _1 = 0]$
; -
(2)
$T := D\varphi (p)$
is diagonal in blocks with respect to the decomposition
$\mathbb {R}^u\times \mathbb {R}\times \mathbb {R}^{s-1}$
; -
(3) in these coordinates,
$\varphi = T$
in
$U_0$
.
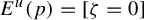
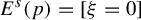
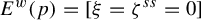
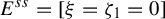
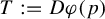
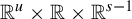


Fix
 $N_0\in \mathbb {N}$
such that
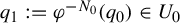 $q_1 := \varphi ^{-N_0}(q_0)\in U_0$
.
Condition C4
Assume that
 $$ \begin{align} D\varphi^{N_0}(q_1)( E^u(p)\oplus E^w(p))\, \cap\, E^{ss}(p) = \{0\}. \end{align} $$
Proposition 4.2. Among the
 $C^{r}$
-diffeomorphisms (
 $r\geq 1$
) with a hyperbolic periodic point admitting a transverse homoclinic intersection, there exists a
 $C^{r}$
-dense set of
 $C^{\infty }$
-diffeomorphisms satisfying the conditions C1–C4 above.
Proof. The
 $C^r$
-density of condition C1 was established in [Reference Avila, Crovisier and Wilkinson2] (see [Reference Bezerra and Moreira3] for a more elementary proof).
Condition C2 is achieved through a
 $C^{r}$
local perturbation around the transversal homoclinic point
 $q_0$
. Using Proposition 2.5, we can approximate, in the
 $C^r$
-topology, the diffeomorphism by a
 $C^\infty $
-diffeomorphism that satisfies condition C3. It is also immediate that condition C4 can be obtained through a
 $C^{r}$
-perturbation.
Let
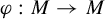 $\varphi :M\to M$
be a
 $C^r$
-diffeomorphism,
 $r\geq 2$
, satisfying conditions C1–C4. Consider
 $N_0\in \mathbb {N}$
such that
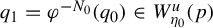 $q_1=\varphi ^{-N_0}(q_0)\in W^u_{\eta _0}(p)$
for some
 $\eta _0$
small enough satisfying that
 $W^u_{\eta _0}(p)$
is contained in the neighborhood
 $U_0$
of p given by condition C3.
For each
 $\delta>0$
, consider the following compact neighborhood of p and
 $q_0$
:
 $$ \begin{align*} V_{\delta} = \{ (\xi,\zeta)\in \mathbb{R}^d\colon\, \lVert\xi\rVert\leq \delta,\, \lVert\zeta\rVert\leq \rho \}\subset U_0, \end{align*} $$
where
 $\rho>0$
is chosen (and then fixed) in such a way that
 $q_0\in V_{\delta }$
. Set
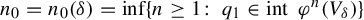 $n_0 = n_0(\delta ) = \inf \{n\geq 1\colon \, q_1\in \textrm {int } \,\varphi ^n(V_{\delta })\}$
. Notice that
 $n_0$
increases as
 $\delta $
goes to zero.
If
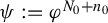 $\psi := \varphi ^{N_0 + n_0}$
, then, for
 $\delta $
small enough,
 $V_\delta \cap \psi (V_{\delta })$
has two connected components, one containing p and another containing
 $q_0$
, denoted by
 $V_1(\delta )$
and
 $V_2(\delta )$
, respectively. Consider the
 $\psi $
-maximal invariant set inside of
 $V_{\delta }$
, that is,
 $$ \begin{align*} \Lambda_0 = \Lambda_0(\delta) := \bigcap_{j\in \mathbb{Z}}\, \psi^j( V_{\delta} ). \end{align*} $$
This is a hyperbolic,
 $\psi $
-invariant set and
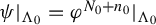 $\psi |_{\Lambda _0} = \varphi ^{N_0+n_0}|_{\Lambda _0}$
is conjugated to a full shift of two symbols
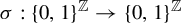 $\sigma :\{0,1\}^{\mathbb {Z}}\to \{0,1\}^{\mathbb {Z}}$
. We also denote by
 $$ \begin{align*} \Lambda := \bigcup_{j=0}^{N_0 + n_0 -1}\, \varphi^{-j}(\Lambda_0) \end{align*} $$
the
 $\varphi $
-invariant hyperbolic set (conjugated to a subshift of finite type) defined by the
 $\varphi ^{-1}$
-orbit of
 $\Lambda _0$
. The horseshoe
 $\Lambda $
has a symbolic structure as described in Proposition 2.2. We denote the stable and unstable bundles of
 $\varphi $
over
 $\Lambda $
by
 $E^s$
and
 $E^u$
, respectively. See [Reference Robinson32, §7.4] for more details about the classical construction of the geometric horseshoe.
In the next proposition, we gather a few properties of the hyperbolic set
 $\Lambda $
.
Proposition 4.3. There exist
 $\delta _0>0$
and
 $\alpha \in (0,1]$
such that for every
 $\delta \in (0,\delta _0)$
, the horseshoe
 $\Lambda $
satisfies the following.
-
(1) The stable bundle
$E^s$
of
$\Lambda $
admits a dominated splitting of the form
$E^s = E^w\oplus E^{ss}$
, with
$\operatorname {dim} E^w= 1$
. -
(2) There exist
$C>0$
and a
$(C,\alpha )$
-Hölder continuous map
$A:W^u_{\mathrm {loc}}(\Lambda )\times W^u_{\mathrm {loc}}(\Lambda )\rightarrow {\mathbb {M}}_{s-1, u+1}(\mathbb {R})$
such that for all
$$ \begin{align*} \lVert A(x,z)\rVert\leq C \quad\text{and}\quad (x-z)_{ss} = A(x,z)(x-z)_{uw} \end{align*} $$
$x,z\in W^u_{\mathrm {loc}}(\Lambda )$
. Moreover,
$A(p,p) = 0$
.
-
(3) For every
$x,y\in {\Lambda }$
,
$y\in W^u_{\delta }(x)$
, the holonomies
$H^u_{x,y} : W^s_{\delta }(x) \cap {\Lambda }\to W^s_{\delta }(y) \cap {\Lambda }$
are
$IC^{1+\alpha }$
. Moreover,
$\Delta H_{x,y}^u(x,x)\, E^w(x) = E^w(y)$
.


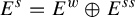
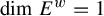


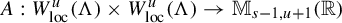


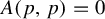


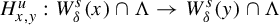

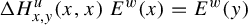
Proof. To prove item (1), we will use the cone field criterion (see [Reference Crovisier and Potrie10, Theorem 2.6]) building first a
 $\psi $
-invariant cone over
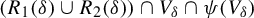 $(R_1(\delta )\cup R_2(\delta ))\cap V_{\delta }\cap \psi (V_{\delta })$
, where
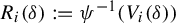 $R_i(\delta ) := \psi ^{-1}(V_i(\delta ))$
,
 $i=1,2$
.
Notice that for every
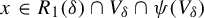 $x\in R_1(\delta )\cap V_{\delta }\cap \psi (V_{\delta })$
and every
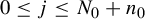 $0\leq j\leq N_0+n_0$
,
 $\varphi ^j(x)\in U_0$
. This implies in particular that for every
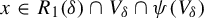 $x\in R_1(\delta )\cap V_{\delta }\cap \psi (V_{\delta })$
,
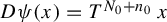 $D\psi (x) = T^{N_0+n_0}\, x$
. Also observe that
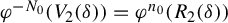 $\varphi ^{-N_0}(V_2(\delta )) = \varphi ^{n_0}(R_2(\delta ))$
is a small neighborhood of
 $q_1$
whose diameter decreases to
 $0$
when
 $\delta $
goes to
 $0$
. Moreover, for every
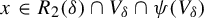 $x\in R_2(\delta )\cap V_{\delta }\cap \psi (V_{\delta })$
and every
 $0\leq j \leq n_0$
,
 $\varphi ^j(x)\in U_0$
and so
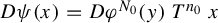 $D\psi (x) = D\varphi ^{N_0}(y)\, T^{n_0}\, x$
, where
 $y = \varphi ^{n_0}(x)$
belongs to the small neighborhood
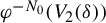 $\varphi ^{-N_0}(V_2(\delta ))$
of
 $q_1$
.
By condition C4, decreasing
 $\delta $
if necessary, there exists
 $\varepsilon>0$
such that for every
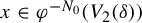 $x\in \varphi ^{-N_0}(V_2(\delta ))$
,
 $$ \begin{align} \measuredangle( D\varphi^{N_0}(x) (E^u(p)\oplus E^w(p)),\, E^{ss}(p) )> \varepsilon > 0. \end{align} $$
For each number
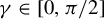 $\gamma \in [0, \pi /2]$
, denote by
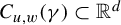 $C_{u,w}(\gamma )\subset \mathbb {R}^d$
the constant cone field over
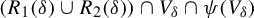 $(R_1(\delta )\cup R_2(\delta )) \cap V_{\delta }\cap \psi (V_{\delta })$
given by the set of directions
 $\mathbb {R}^d$
whose angle with respect to
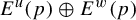 $E^u(p)\oplus E^w(p)$
is at most
 $\gamma $
. Consider a positive number
 $\tau>0$
satisfying that for every
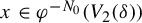 $x\in \varphi ^{-N_0}(V_2(\delta ))$
,
 $$ \begin{align} D\varphi^{N_0}(x)\, C_{u,w}(\tau) \subset \operatorname{Int} C_{u,w}( \pi/2 - \varepsilon/2 ). \end{align} $$
This is achieved using inequality (4.2). Diminishing
 $\delta $
once more, we may also assume that
 $$ \begin{align} T^{n_0}\, C_{u,w}(\pi/2-\varepsilon/2) \subset \operatorname{Int} C_{u,w}(\tau). \end{align} $$
This is because any direction which is not inside of
 $E^{ss}(p)$
converges to
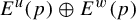 $E^u(p)\oplus E^w(p)$
through T iterations, and so the cone
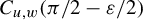 $C_{u,w}(\pi /2-\varepsilon /2)$
will be contracted in the
 $E^u(p)\oplus E^w(p)$
direction.
For any
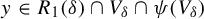 $y\in R_1(\delta )\cap V_{\delta }\cap \psi (V_{\delta })$
and
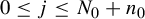 $0\leq j \leq N_0+n_0$
,
 $\varphi ^j(y)\in U_0$
and so,
 $$ \begin{align*} D\psi(y)\, C_{u,w}(\pi/2-\varepsilon/2) \subset \operatorname{Int} C_{u,w}(\pi/2-\varepsilon/2). \end{align*} $$
Now, for
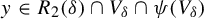 $y\in R_2(\delta )\cap V_{\delta }\cap \psi (V_{\delta })$
,
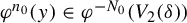 $\varphi ^{n_0}(y)\in \varphi ^{-N_0}(V_2(\delta ))$
. In particular, by (4.3) and (4.4), we have
 $$ \begin{align*} D\psi(y)\, C_{u,w}(\pi/2-\varepsilon/2) &= D\varphi^{N_0}(\varphi^{n_0}(y))\, T^{n_0}\, C_{u,w}(\pi/2-\varepsilon/2)\\ &\subset \operatorname{Int} D\varphi^{N_0}(\varphi^{n_0}(y))\, C_{u,w}(\tau)\\ &\subset \operatorname{Int} C_{u,w}(\pi/2-\varepsilon/2). \end{align*} $$
Thus, the constant cone field
 $C_{u,w}(\pi /2-\varepsilon /2)$
over
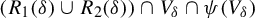 $(R_1(\delta )\cup R_2(\delta ))\cap V_{\delta }\cap \psi (V_{\delta })$
is invariant by the action of
 $D\psi $
.
A similar argument shows that the complementary cone field of
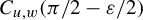 $C_{u,w}(\pi /2-\varepsilon /2)$
, namely
 $C_{ss}(\varepsilon /2)$
, defined as the set of directions in
 $\mathbb {R}^d$
whose angle with the space
 $E^{ss}$
does not exceed
 $\varepsilon /2$
, is invariant by the backwards action
 $D\psi ^{-1}$
over
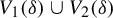 $V_1(\delta )\cup V_2(\delta )$
. However, in this case, we need an additional modification of
 $\delta _0$
ensuring that
 $$ \begin{align*} T^{-n_0}\, C_{ss}(\pi/2 - \tau) \subset \operatorname{Int} C_{ss}(\varepsilon/2), \end{align*} $$
where
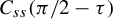 $C_{ss}(\pi /2 - \tau )$
is defined analogously as before.
Thus, over
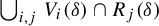 $\bigcup _{i,j}V_i(\delta )\cap R_j(\delta )$
, we have a pair of cone fields
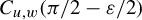 $C_{u,w}(\pi /2-\varepsilon /2)$
and
 $C_{ss}(\varepsilon /2)$
invariant by
 $D\psi $
and
 $D\psi ^{-1}$
, respectively. Applying the cone field criterion, we have a dominated splitting over
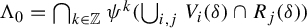 $\Lambda _0 = \bigcap _{k\in \mathbb {Z}} \psi ^k(\bigcup _{i,j}V_i(\delta )\cap R_j(\delta ))$
given by
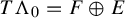 $T\Lambda _0 = F\oplus E$
, where for every
 $x\in \Lambda _0$
,
 $$ \begin{align*} F(x) &= \bigcap_{j\geq 0}D\psi^j(\psi^{-j}(x))\, C_{uw}(\pi/2-\varepsilon/2) \quad \text{and}\\ E(x) &= \bigcap_{j\geq 0}D\psi^{-j}(\psi^j(x))\, C_{ss}(\varepsilon/2). \end{align*} $$
Notice that
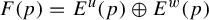 $F(p) = E^u(p)\oplus E^w(p)$
and
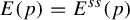 $E(p) = E^{ss}(p)$
. Also,
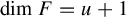 $\operatorname {dim} F = u + 1$
and
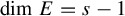 $\operatorname {dim} E = s-1$
. Moreover,
 $E\subset E^s$
. Set
 $$ \begin{align*} E^w := F\cap E^s \quad E^{ss} := E \subset E^s. \end{align*} $$
These are
 $D\psi $
-invariant continuous bundles and they give the dominated splitting
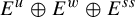 $E^u\oplus E^w \oplus E^{ss}$
of
 $T\Lambda _0$
. Iterating this dominated splitting using the diffeomorphism
 $\varphi $
, we construct a dominated splitting for
 $\Lambda $
. This concludes the proof of item (1).
For a proof of item (2), see [Reference Palis and Viana28, Proposition 3.2]. The regularity of the holonomies
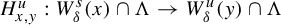 $H^u_{x,y}:W^s_{\delta }(x)\cap \Lambda \to W^u_{\delta }(y)\cap \Lambda $
expressed in item (3) is obtained in [Reference Palis and Viana28, Proposition 3.5]. The proof of [Reference Palis and Viana28, Proposition 3.5] also gives the existence of
 $C>0$
, uniform for
 $\Delta H^u_{x,y}$
in a compact neighborhood, such that
 $$ \begin{align} \sup_{z\in W^s_{\delta}(x)\cap \Lambda}\lVert \Delta H^u_{x,y}(z,z) - I \rVert\leq C\, d(x,y). \end{align} $$
Indeed, the argument in [Reference Palis and Viana28] characterizes
 $\Delta H^u_{x,y}$
as the unique solution
 $\Gamma (t;z_1,z_2)$
, with
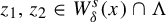 $z_1,z_2\in W^s_{\delta }(x)\cap \Lambda $
, of an initial value problem
 $$ \begin{align} \begin{cases} \dfrac{d}{dt}\Gamma(t;z_1,z_2) = L(t;z_1,z_2)\cdot \Gamma(t;z_1,z_2), \\[3pt] \Gamma(0,z_1,z_2) = I, \end{cases} \end{align} $$
where
 $L(t;z_1,z_2)$
is a linear transformation depending continuously on
 $t\in [0,\xi ]$
, with
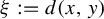 $\xi := d(x,y)$
, and on the variables
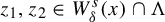 $z_1,z_2\in W^s_{\delta }(x)\cap \Lambda $
. Therefore, the inequality (4.5) is a consequence of the mean value theorem applied to the function
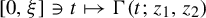 $[0,\xi ] \ni t\mapsto \Gamma (t;z_1,z_2)$
together with the boundness of its derivative in (4.6), obtained by continuity of L and compactness of
 $\Lambda \times \Lambda $
.
Now, we prove that the intrinsic derivative of the holonomy preserves the weak stable bundle. For every
 $n\geq 1$
, write
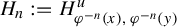 $H_n := H^u_{\varphi ^{-n}(x),\, \varphi ^{-n}(y)}$
for the unstable holonomy connecting
 $\varphi ^{-n}(x)$
to
 $\varphi ^{-n}(y)$
. By the invariance of the holonomy (2.5), we may write, for every
 $n\geq 1$
,
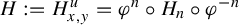 $H := H^u_{x,y} = \varphi ^n\circ H_n\circ \varphi ^{-n}$
. Thus,
 $$ \begin{align} \Delta H(x,x) = \Delta\varphi^n( H_n(\varphi^{-n}(x)), H_n(\varphi^{-n}(x)) )\, \Delta H_n(\varphi^{-n}(x),\varphi^{-n}(x))\, \Delta\varphi^{-n}(x,x). \end{align} $$
Consider
 $v\in E^w(x)$
and write
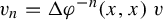 $v_n = \Delta \varphi ^{-n}(x,x)\, v$
and
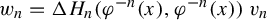 $w_n = \Delta H_n(\varphi ^{-n}(x),\varphi ^{-n}(x))\, v_n$
. Notice that
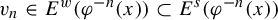 $v_n\in E^w(\varphi ^{-n}(x))\subset E^s(\varphi ^{-n}(x))$
and
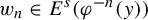 $w_n\in E^s(\varphi ^{-n}(y))$
. Since
 $y\in W^u_{\delta }(x)$
, we have that
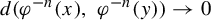 $d(\varphi ^{-n}(x),\, \varphi ^{-n}(y))\to 0$
as
 $n\to \infty $
and so,
 $$ \begin{align} d(E^{ss}(\varphi^{-n}(y)), E^{ss}(\varphi^{-n}(x))) \to 0. \end{align} $$
Furthermore, by inequality (4.5), there exists a constant
 $C>0$
such that
 $$ \begin{align} \lVert \Delta H_n(\varphi^{-n}(x),\,\varphi^{-n}(x)) - I \rVert \leq\, C\, d(\varphi^{-n}(x),\, \varphi^{-n}(y)). \end{align} $$
Using the fact that the splitting
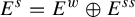 $E^s = E^w\oplus E^{ss}$
is dominated, we have that there exists
 $C_1>0$
such that
 $$ \begin{align} \measuredangle( E^w(\varphi^{-n}(x)),\, E^{ss}(\varphi^{-n}(x)) )\geq C_1> 0 \end{align} $$
for every
 $n\geq 0$
. Hence, by (4.8), (4.9), and (4.10), there exists
 $C_2>0$
and
 $n_1\in \mathbb {N}$
such that for every
 $n\geq n_1$
, we have
 $$ \begin{align*} \measuredangle( w_n,\, E^{ss}(\varphi^{-n}(y)) )\geq C_2> 0. \end{align*} $$
Since
 $E^w$
is an attractor for the
 $D\varphi $
-action, we obtain that
 $$ \begin{align*} \measuredangle( \Delta\varphi^n( H_n(\varphi^{-n}(x)), H_n(\varphi^{-n}(x)) )\, w_n,\, E^w(y) )\to 0, \end{align*} $$
as
 $n\to \infty $
. Therefore, by (4.7),
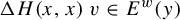 $\Delta H(x,x)\, v\in E^w(y)$
. This finishes the proof of item (3) and the proposition.
4.2 Construction of the regular Cantor set
Let
 ${\tilde {\Lambda }}$
be a sub-horseshoe of
 $\Lambda $
containing p. Observe that
 $\tilde {\Lambda }$
has a dominated splitting of the form
 $E^u\oplus E^w\oplus E^{ss}$
, which is given by the restriction of the splitting on
 $T\Lambda $
. Furthermore, the holonomies on
 $\tilde {\Lambda }$
, being the restriction of holonomies on
 $\Lambda $
, are also intrinsically
 $C^{1+\alpha }$
. We may also restrict the map
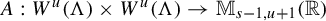 $A: W^u(\Lambda )\times W^u(\Lambda )\to \mathbb {M}_{s-1, u+1}(\mathbb {R})$
to
 $W^u(\tilde {\Lambda })\times W^u(\tilde {\Lambda })$
, while keeping the same properties as those described in item (2) of Proposition 4.3.
Consider the
 $\psi $
-invariant set,
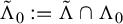 $\tilde {\Lambda }_0 := \tilde {\Lambda }\cap \Lambda _0$
and notice that
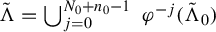 $\tilde {\Lambda } = \bigcup _{j=0}^{N_0+n_0 - 1}\, \varphi ^{-j}(\tilde {\Lambda }_0)$
. Let
 $\tilde {V}_0$
be a small neighborhood of p such that
 $\tilde {\Lambda }_0\cap \tilde {V}_0$
has a product structure. Then, there exists
 $\eta _1>0$
small enough such that for every
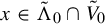 $x\in \tilde {\Lambda }_0\cap \tilde {V}_0$
,
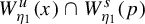 $W^u_{\eta _1}(x)\cap W_{\eta _1}^s(p)$
is a single point contained in
 $\tilde {\Lambda }_0$
. Define the projection
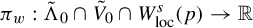 $\pi _w:\tilde {\Lambda }_0 \cap \tilde {V}_0\cap W^s_{\mathrm {loc}}(p)\to \mathbb {R}$
,
 $$ \begin{align*} \pi_w(\xi_u,\ldots, \xi_1, \zeta_1,\ldots, \zeta_s) = \zeta_1. \end{align*} $$
Notice that
 $\pi _w$
is a homeomorphism onto its image
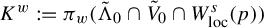 $K^w:= \pi _w(\tilde {\Lambda }_0\cap \tilde {V}_0\cap W^s_{\mathrm {loc}}(p))$
. Indeed, by item (2) of Proposition 4.3, for every
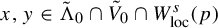 $x,y\in \tilde {\Lambda }_0\cap \tilde {V}_0\cap W^s_{\mathrm {loc}}(p)$
,
 $$ \begin{align*} \lVert x-y\rVert &= \lVert (0_u, (x-y)_w, (x-y)_{ss}) \rVert\\ &= \lVert (0_u, \pi_w(x) - \pi_w(y), A(x,y)\, (0_u, \pi_w(x) - \pi_w(y))) \rVert\\ &\leq (1+C)|\pi_w(x) - \pi_w(y)|. \end{align*} $$
In particular, this implies that
 $\pi _w^{-1}$
is a Lipschitz function from
 $K^w$
to
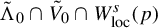 $\tilde {\Lambda }_0\cap \tilde {V}_0\cap W^s_{\mathrm {loc}}(p)$
. Furthermore, we can define an intrinsic derivative to
 $\pi _w^{-1}$
in the following way: for any
 $t,s \in K^w$
, set
 $$ \begin{align} \Delta\pi_w^{-1}(t,s):= ( 1_w,\, A(\pi_w^{-1}(t),\, \pi_w^{-1}(s))\, (0_u,\, 1_w) ) \in \mathbb{M}_{s,w}(\mathbb{R}). \end{align} $$
Thus,
 $$ \begin{align*} \Delta\pi_w^{-1}(t,s)\, (t-s) &= ( t-s,\, A(\pi_w^{-1}(t),\, \pi_w^{-1}(s))\, (0_u,\, t-s) )\\ &= ( t-s, A(\pi_w^{-1}(t),\, \pi_w^{-1}(s))\, (\pi_w^{-1}(t) - \pi_w^{-1}(s))_{uw} )\\ &= (t-s, (\pi_w^{-1}(t) - \pi_w^{-1}(s))_{ss}) = \pi_w^{-1}(t) - \pi_w^{-1}(s). \end{align*} $$
Since
 ${\tilde {\Lambda }}_0$
is a horseshoe for
 $\psi $
, an appropriate coding for
 $\psi |_{{\tilde {\Lambda }}_0}$
allows us to identify elements in
 ${\tilde {\Lambda }}_0$
with sequences
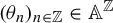 $(\theta _n)_{n\in \mathbb {Z}}\in \mathbb {A}^{\mathbb {Z}}$
, with symbols in some finite alphabet
 $\mathbb {A}$
and admissibility given by a transition matrix B. Moreover, the dynamics
 $\psi |_{{\tilde {\Lambda }}_0}$
is conjugated to the shift transformation on the set of B-admissible sequences (see §2.3).
We denote the fixed point p using the symbolic representation by
 $p = (\bar {0})$
. We write
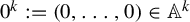 $0^{k} := (0,\ldots , 0)\in \mathbb {A}^{k}$
for every
 $k\in \mathbb {N}$
and
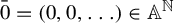 $\bar {0} = (0,0,\ldots )\in \mathbb {A}^{\mathbb {N}}$
. In this section, it will be useful to express a point
 $x\in {\tilde {\Lambda }}_0$
by concatenating a collection of finite words in
 $\bigcup _{m\in \mathbb {N}}\mathbb {A}^m$
, say
 $$ \begin{align*} x = (\ldots, b_{-n+1},\ldots, b_{-1}, b_0^{\ast}, b_1,\ldots, b_{n-1},\ldots), \end{align*} $$
with
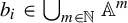 $b_i\in \bigcup _{m\in \mathbb {N}}\mathbb {A}^m$
. Here, the
 $\ast $
indicates the position of the zeroth coordinate of the sequence which, in this case, is located at one of the coordinates of a finite word
 $b_0$
.
Using this symbolic notation, we write
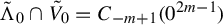 ${\tilde {\Lambda }}_0\cap \tilde {V}_0 = C_{-m+1}(0^{2m-1})$
, with
 $m\in \mathbb {N}$
. Take
 $l>2m$
and set
 $$ \begin{align*} \hat{W}_l := \bigcup_{b:\, |b|=l-2m+1}\, \hat{W}_{b,l}, \end{align*} $$
where the union is taken over finite (
 ${\tilde {\Lambda }}_0$
-admissible for
 $\psi $
) words
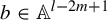 $b\in \mathbb {A}^{l-2m+1}$
and
 $$ \begin{align*} \hat{W}_{b,l} := \bigcap_{j\geq 0}\, \psi^{jl}( C_{-m+1}(0^{2m-1}) )\cap C_m(b\, \bar{0}) \subset {\tilde{\Lambda}}_0. \end{align*} $$
So, for each
 $x\in \hat {W}_{b,l}$
, there exists a sequence
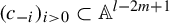 $(c_{-i})_{i> 0}\subset \mathbb {A}^{l-2m+1}$
such that
 $$ \begin{align*} x = (\ldots, c_{-i+1},\, 0^{2m-1},\, c_{-i+2}, \ldots, \, {0}^{2m-1}, \, c_{-2},\, {0}^{2m-1}, \, c_{-1},\, 0^{2m-1\ast},\, b,\, \bar{0}), \end{align*} $$
where the
 $\ast $
is placed at the center of the word
 $0^{2m-1}$
. Write
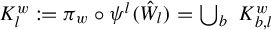 $K^w_l := \pi _w\circ \psi ^l(\hat {W}_l) = \bigcup _b\, K^w_{b,l}$
, with
 $K^w_{b,l} := \pi _w\circ \psi ^l(\hat {W}_{b,l})$
.
Proposition 4.4. For every sufficiently large
 $l> 2m$
, the set
 $K^w_l$
is a regular Cantor set. Moreover,
 $$ \begin{align*} IT_0\, K^w_l = \Delta\, \pi_w(0,0)\cdot E^w(p). \end{align*} $$
Proof. By the local product structure on
 $\tilde {V}_0\cap \tilde {\Lambda }_0$
,
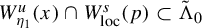 $W^u_{\eta _1}(x)\cap W^s_{\mathrm {loc}}(p)\subset {\tilde {\Lambda }}_0$
is a singleton, which we denote by
 $\{\pi _s(x)\}$
. By item (3) of Proposition 4.3, we see that
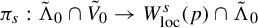 $\pi _s:{\tilde {\Lambda }}_0\cap \tilde {V}_0\to W^s_{\mathrm {loc}}(p)\cap {\tilde {\Lambda }}_0$
is an intrinsic
 $C^{1+\alpha }$
map.
Now, we define the
 $IC^{1+\alpha }$
map
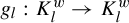 $g_l:K^w_l\to K^w_l$
by
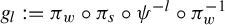 $g_l := \pi _w\circ \pi _s\circ \psi ^{-l}\circ \pi _w^{-1}$
, which defines the regular Cantor set structure on
 $K^w_l$
. First, we need to ensure that this map is well defined, meaning that for every
 $t\in K^w_l$
,
 $g_l(t)\in K^w_l$
. Indeed, by definition of
 $K^w_l$
,
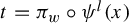 $t = \pi _w\circ \psi ^l(x)$
with
 $$ \begin{align*} x = (\ldots, c_{-i+1},\, 0^{2m-1},\, c_{-i+2}, \ldots, c_{-1},\, 0^{2m-1\ast},\, c_0,\, \bar{0}) \end{align*} $$
for a sequence of finite words
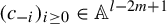 $(c_{-i})_{i\geq 0} \in \mathbb {A}^{l-2m+1}$
. Notice that by the local product structure, we can also characterize
 $\pi _s(x)$
symbolically:
 $$ \begin{align*} \pi_s(x) = (\ldots, c_{-i+1},\, 0^{2m-1},\, c_{-i+2}, \ldots, c_{-1},\, 0^{2m-1\ast},\, \bar{0}) \in W^u_{\eta_1}(x)\cap W^s_{\mathrm{loc}}(p). \end{align*} $$
In particular, we can write
 $$ \begin{align*} \pi_s(x) = \psi^l(\ldots, c_{-i},\, 0^{2m-1},\, c_{-i+1}, \ldots, c_{-2},\, 0^{2m-1\ast},\, c_{-1},\, 0^{2m-1},\, \bar{0}), \end{align*} $$
implying that
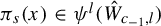 $\pi _s(x) \in \psi ^l(\hat {W}_{c_{-1}, l})$
. So,
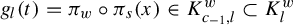 $g_l(t) = \pi _w\circ \pi _s(x) \in K^w_{c_{-1}, l}\subset K^w_l$
. Thus,
 $g_l$
is a well-defined map.
The restriction
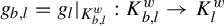 $g_{b,l} = g_l|_{K^w_{b,l}}: K^w_{b,l}\to K_l^w$
, for
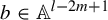 $b\in \mathbb {A}^{l-2m+1}$
admissible, is a homeomorphism. From the above computation, the injectivity is clear. To show that
 $g_{b,l}$
is onto, consider
 $s \in K^w_l$
, then we can write
 $$ \begin{align*} \pi_w^{-1}(s) &= \psi^l(\ldots, c_{-i+1},\, 0^{2m-1},\, c_{-i+2}, \ldots, c_{-1},\, 0^{2m-1\ast},\, c_0,\, \bar{0})\\ &= (\ldots, c_{-i},\, 0^{2m-1},\, c_{-i+1}, \ldots, c_{0},\, 0^{2m-1\ast},\, \bar{0}) \in \psi^l(\hat{W}_l) \end{align*} $$
for some sequence
 $(c_{-i})_{i\geq 0}$
. Write
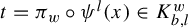 $t = \pi _w\circ \psi ^l(x)\in K^w_{b,l}$
, where
 $x\in \hat {W}_{b,l}$
satisfies
 $$ \begin{align*} x = (\ldots, c_{-i},\, 0^{2m-1},\, c_{-i+1}, \ldots, c_{0},\, 0^{2m-1\ast},\, b,\, \bar{0}). \end{align*} $$
Then,
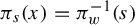 $\pi _s(x) = \pi _w^{-1}(s)$
and so
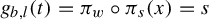 $g_{b,l}(t) = \pi _w\circ \pi _s(x) = s$
. Thus, the map
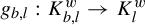 $g_{b,l}:K^w_{b,l}\to K^w_l$
is invertible and continuous. From the compactness of
 $K^w_{b,l}$
, we conclude that
 $g_{b,l}$
is a homeomorphism for every
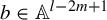 $b\in \mathbb {A}^{l-2m+1}$
admissible.
Furthermore, since
 $\pi _s$
is
 $IC^{1+\alpha }$
, we have that for each b admissible and l sufficiently large,
 $g_{b,l}$
is an
 $IC^{1+\alpha }$
map satisfying
 $\lVert \Delta g_{b,l}(s,t)\rVert \geq 2$
for every
 $t,s\in K^w_{b,l}$
. Moreover,
 $\text {Hull}(K^w_{b,l})\cap \text {Hull}(K^w_{b',l}) = \varnothing $
for every
 $b\neq b'$
. In particular, using an extension result [Reference Palis and Viana28, Lemma 4.4], we deduce that
 $K^w_l$
is a
 $C^{1+\alpha }$
regular Cantor set.
To finish the proof of the proposition, observe that by item (2) of Proposition 4.3, we have that
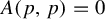 $A(p, p) = 0$
and so by (4.11),
 $$ \begin{align*} \Delta \pi_w^{-1}(0,0) = (1_w,\, A(p,p)(0_u,1_w)) = (1_w, 0_{ss})\in E^w(p). \end{align*} $$
Therefore,
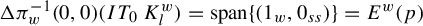 $\Delta \pi _w^{-1}(0,0)(IT_0\, K^w_l) = \text {span}\{(1_w,0_{ss})\} = E^w(p)$
.
Corollary 4.5. The compact set
 $$ \begin{align*} K^w(\varphi) := \pi_w^{-1}(K^w) \subset W^s_{\mathrm{loc}}(p)\cap \tilde\Lambda_0 \end{align*} $$
has a Cantor set structure with
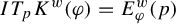 $IT_pK^w(\varphi ) = E^w_{\varphi }(p)$
.
4.3 Stability machinery
Fix
 $r\geq 1$
. In this whole section, we assume that
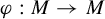 $\varphi :M\to M$
is a
 $C^r$
-diffeomorphism satisfying properties C1–C4 (see §4.1).
For any
 $C^r$
-diffeomorphism
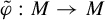 $\tilde {\varphi }:M\to M$
,
 $C^1$
close to
 $\varphi $
, write
 $p(\tilde {\varphi })$
and
 $\Lambda (\tilde {\varphi })$
respectively for the analytic continuation for
 $\tilde {\varphi }$
of the fixed point p and the horseshoe
 $\Lambda = \Lambda (\varphi )$
associated with
 $\varphi $
.
The next proposition is an immediate generalization of Proposition 4.3 for diffeomorphisms
 $\tilde {\varphi }$
which are
 $C^1$
-close to
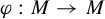 $\varphi :M\to M$
. Analogously to what is described in §4.1, we use the systems of coordinates provided by the dominated splitting
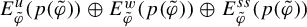 $E^u_{\tilde {\varphi }}(p(\tilde {\varphi }))\oplus E^w_{\tilde {\varphi }}(p(\tilde {\varphi }))\oplus E^{ss}_{\tilde {\varphi }}(p(\tilde {\varphi }))$
at the
 $\tilde {\varphi }$
-fixed point
 $p(\tilde {\varphi })$
. Hence, when writing
 $x_*$
for
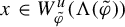 $x\in W^u_{\tilde {\varphi }}(\Lambda (\tilde {\varphi }))$
, we mean the projection of x in the
 $E^*_{\tilde {\varphi }}(p(\tilde {\varphi }))$
direction, with
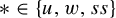 $*\in \{u,w,ss\}$
.
The suitable use of the above coordinate system is the key point to adjust the arguments established in [Reference Palis and Viana28] from a diffeomorphism satisfying the conditions C1–C4 to its perturbations. A straightforward adaptation of the arguments described in the proof of Proposition 4.3 is sufficient to obtain the following proposition.
Proposition 4.6. There exist positive numbers
 $\delta _0,\alpha , C>0$
and a
 $C^1$
-neighborhood
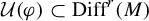 $\mathcal {U}(\varphi )\subset \operatorname {Diff}^r(M)$
of
 $\varphi $
such that for every
 $0<\delta < \delta _0$
and for every
 $\tilde {\varphi }\in \mathcal {U}(\varphi )$
, one has the following.
-
(1) The stable bundle
$E^s_{\tilde {\varphi }}$
of
$\Lambda ({\tilde {\varphi }})$
admits a dominated splitting of the form
$E^s_{\tilde {\varphi }} = E^w_{\tilde {\varphi }}\oplus E^{ss}_{\tilde {\varphi }}$
, with
$\operatorname {dim} E^w_{\tilde {\varphi }}= 1$
. -
(2) There exist
$C>0$
and a
$(C,\alpha )$
-Hölder continuous map
$A_{\tilde {\varphi }}:W^u_{\tilde {\varphi },\mathrm {loc}}(\Lambda (\tilde {\varphi }))\times W^u_{\tilde {\varphi },\mathrm {loc}}(\Lambda (\tilde {\varphi }))\to \mathcal {L}(E^u_{\tilde {\varphi }}(p(\tilde {\varphi }))\times E^w_{\tilde {\varphi }}(p(\tilde {\varphi }));E^{ss}_{\tilde {\varphi }}(p(\tilde {\varphi })))$
such that for all
$$ \begin{align*} \lVert A_{\tilde{\varphi}}(x,z)\rVert\leq C \quad\text{and}\quad (x-z)_{ss} = A_{\tilde{\varphi}}(x,z)(x-z)_{uw} \end{align*} $$
$x,z\in W^u_{\tilde {\varphi },\mathrm {loc}}(\Lambda (\tilde {\varphi }))$
. Moreover,
$A_{\tilde {\varphi }}(p(\tilde {\varphi }),p(\tilde {\varphi })) = 0$
.
-
(3) Assume
$r\geq 2$
. For every
$x,y\in \Lambda ({\tilde {\varphi }})$
,
$y\in W^u_{\tilde {\varphi },\delta }(x)$
, the holonomies
$H^u_{\tilde {\varphi },x,y} : W^s_{\tilde {\varphi },\delta }(x) \cap \Lambda ({\tilde {\varphi }})\to W^s_{\tilde {\varphi },\delta }(y) \cap \Lambda ({\tilde {\varphi }})$
are
$IC^{1+\alpha }$
. Moreover,
$\Delta H_{\tilde {\varphi },x,y}^u(x,x)\, E^w_{\tilde {\varphi }}(x) = E^w_{\tilde {\varphi }}(y)$
.


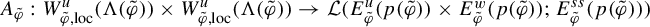

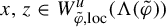
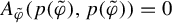

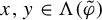
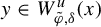
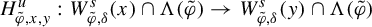

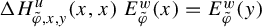
Now, we fix a neighborhood
 $\mathcal {V}(\varphi )$
of
 $\varphi $
, such that the Proposition 4.6 holds and there exists a map
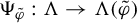 $\Psi _{\tilde {\varphi }}:\Lambda \to \Lambda ({\tilde {\varphi }})$
that conjugates
 $\varphi |_{\Lambda }$
and
 $\tilde {\varphi }|_{\Lambda (\tilde {\varphi })}$
. It is well established that this map is bi-Hölder continuous with a uniform Hölder constant and exponent in a
 $C^1$
-neighborhood of
 $\varphi $
in
 $\operatorname {Diff}^r(M)$
(see [Reference Katok and Hasselblatt17]).
The next proposition ensures that any sub-horseshoe of a diffeomorphism in
 $\mathcal {V}(\varphi )$
contains compact sets with positive Hausdorff dimension and with controlled geometry in a point. This is the most important geometric tool here and it will be essential for proof of the main results.
Proposition 4.7. Fix
 $r\geq 2$
. For every
 $\tilde {\varphi } \in \mathcal {V(\varphi )}$
and for any sub-horseshoe
 ${\tilde {\Lambda }}(\tilde {\varphi })$
of
 $\Lambda (\tilde {\varphi })$
for
 $\tilde {\varphi }$
, we can find a compact set
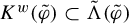 $K^w(\tilde {\varphi })\subset \tilde {\Lambda }(\tilde {\varphi })$
containing the analytic continuation of the fixed point p of
 $\varphi $
for
 $\tilde {\varphi }$
,
 $p(\tilde {\varphi })$
, such that:
-
(i)
$\operatorname {dim}_H(K^w(\tilde {\varphi }))>0$
; -
(ii)
$IT_{p(\tilde {\varphi })}\, K^w(\tilde {\varphi }) = E^w_{\tilde {\varphi }}(p(\tilde {\varphi }))$
.
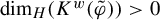
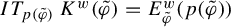
Proof. Take
 $\tilde {\varphi }\in \mathcal {V}(\tilde {\varphi })$
and let
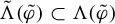 ${\tilde {\Lambda }}(\tilde {\varphi })\subset \Lambda (\tilde {\varphi })$
be a sub-horseshoe for
 $\tilde {\varphi }$
. This sub-horseshoe is the analytic continuation of a sub-horseshoe of
 $\Lambda $
for
 $\varphi $
denoted by
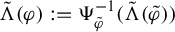 ${\tilde {\Lambda }}(\varphi ) := \Psi ^{-1}_{\tilde {\varphi }}({\tilde {\Lambda }}(\tilde {\varphi }))$
.
Define the set
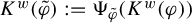 $K^w(\tilde {\varphi }):= \Psi _{\tilde {\varphi }}(K^w(\varphi ))$
, where
 $K^w(\varphi )$
is the subset of
 $\tilde {\Lambda }(\varphi )$
with a regular Cantor set structure given by Corollary 4.5. Using the fact that
 $\Psi _{\tilde {\varphi }}$
is a conjugacy between
 $\Lambda $
and
 $\Lambda (\tilde {\varphi })$
and the inclusion
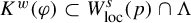 $K^w(\varphi ) \subset W^s_{\mathrm {loc}}(p)\cap \Lambda $
(see Corollary 4.5), we have that
 $$ \begin{align*} p(\tilde{\varphi}) \in K^w(\tilde{\varphi}) \subset W^s_{\tilde{\varphi},\mathrm{loc}}(p(\tilde{\varphi}))\cap \tilde{\Lambda}(\tilde{\varphi}). \end{align*} $$
Since the image of sets with positive Hausdorff dimension under Hölder transformations has positive Hausdorff dimension, one has
 $$ \begin{align*} \operatorname{dim} K^w(\tilde{\varphi})>0. \end{align*} $$
This concludes the proof of item (i). To prove item (ii), we can use property (2) of Proposition 4.6 to ensure that
 $IT_{p(\tilde {\varphi })}{\tilde {\Lambda }}(\tilde {\varphi })$
coincides with
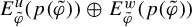 $E^u_{\tilde {\varphi }}(p(\tilde {\varphi }))\oplus E^w_{\tilde {\varphi }}(p(\tilde {\varphi }))$
(by the definition of the intrinsic tangent space). Since
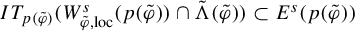 $IT_{p(\tilde {\varphi })}(W^s_{\tilde {\varphi },\mathrm {loc}}(p(\tilde {\varphi }))\cap {\tilde {\Lambda }}(\tilde {\varphi }))\subset E^s(p(\tilde {\varphi }))$
, we have
 $$ \begin{align*} IT_{p(\tilde{\varphi})}K^w(\tilde{\varphi}) = IT_{p(\tilde{\varphi})}(W^s_{\tilde{\varphi},\mathrm{loc}}(p(\tilde{\varphi}))\cap {\tilde{\Lambda}}(\tilde{\varphi})) = E^w_{\tilde{\varphi}}(p(\tilde{\varphi})). \end{align*} $$
This finishes the proof of Proposition 4.7.
Remark 4.8. Even though the authors believe that the compact set
 $K^w(\tilde {\varphi })$
has a Cantor set structure, the techniques developed here only ensure the control of its geometry at a single point, namely
 $p(\tilde {\varphi })$
.
4.4 Choice of the potential
In this section, we construct a large set of potentials in
 $C^1(M;\mathbb {R})$
that will be used in Theorem C. We also deal with a general horseshoe
 $\Lambda $
for a diffeomorphism
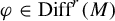 $\varphi \in \operatorname {Diff}^r(M)$
containing a point
 $p\in \Lambda $
which is fixed by
 $\varphi $
.
Let
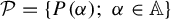 $\mathcal {P} = \{P(\alpha );\ \alpha \in \mathbb {A}\}$
be a Markov partition for the horseshoe
 $\Lambda $
associated with
 $\varphi $
and let
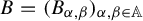 $B=(B_{\alpha , \beta })_{\alpha , \beta \in \mathbb {A}}$
be the related transition matrix (see §2.3). For each finite word
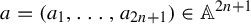 $a = (a_1,\ldots , a_{2n+1})\in \mathbb {A}^{2n+1}$
, we consider the box
 $$ \begin{align*} P(a) := \bigcap_{i=-n}^{n}\varphi^{-i}(P(a_{i+n+1})). \end{align*} $$
The set of all the boxes
 $P(a)$
, where a varies over the admissible words in
 $\mathbb {A}^{2n+1}$
, will be denoted by
 $\mathcal {P}^n$
. Notice that
 $\mathcal {P}^n$
also forms a Markov partition for
 $\Lambda $
.
For each
 $x\in \Lambda $
, fix one unit vector
 $e^w(x)$
in
 $E^w(x)$
so that
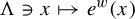 $\Lambda \ni x\mapsto e^w(x)$
is continuous. Let
 $\mathcal {X}_{\varphi }$
be the set of functions
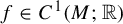 $f\in C^1(M;\mathbb {R})$
satisfying that there exist
 $n\in \mathbb {N}$
and an admissible word
 $a\in \mathbb {A}^{2n+1}$
such that:
-
(1)
$p\notin P(a)$
; -
(2)
$\inf _{x \in P(a)} f(x)> \sup _{x \in \Lambda \backslash P(a)}f(x)$
; -
(3)
$\inf _{x\in P(a)}|\nabla f(x)\cdot e^w(x)|> 0$
;


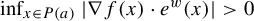
Proposition 4.9. The set
 $\mathcal {X}_{\varphi }$
is open and dense in
 $C^1(M;\mathbb {R})$
.
Proof. Since the maps f,
 $\nabla f$
, and
 $\Lambda \ni y \mapsto e^w(y)$
are continuous, by compactness of the horseshoe, we see that conditions (1)–(3) are
 $C^1$
-open. Hence,
 $\mathcal {X}_\varphi $
is open in
 $C^1(M;\mathbb {R})$
.
It remains to show that
 $\mathcal {X}_\varphi $
is
 $C^1$
-dense. For this purpose, fix
 $\varepsilon>0$
and consider
 $f \in C^1(M; \mathbb {R})$
. Let
 $x_0 \in \Lambda $
be a maximal point of f on
 $\Lambda $
. Up to a small perturbation on f, we may assume that
 $x_0$
does not coincide with the fixed point
 $p\in \Lambda $
.
Now, we divide the proof into two cases. First, we assume that
 $\nabla f(x_0)\cdot e^w(x_0) \neq 0$
. Here, we can consider
 $n\in \mathbb {N}$
big enough and a finite admissible word
 $a\in \mathbb {A}^{2n+1}$
such that
 $p\notin P(a)$
,
 $x_0\in P(a)$
, and for every
 $x\in P(a)$
,
 $$ \begin{align} \nabla f(x) \cdot e^w(x) \neq 0 \quad\text{and}\quad f(x)> f(x_0)-\varepsilon/2. \end{align} $$
Thus, using inequality (4.12), we can see that the function
 $g:\Lambda \to \mathbb {R}$
defined by
 $$ \begin{align*} g(x) = \begin{cases} f(x) + \varepsilon/2, & x\in P(a), \\ f(x), & x\in \Lambda\backslash P(a), \end{cases} \end{align*} $$
satisfies conditions (2) and (3) in the definition of
 $\mathcal {X}_{\varphi }$
with n and
 $P(a)$
given above. So, we can consider a partition of unity to extend g to a
 $C^1$
function
 $\tilde {g}: M \to \mathbb {R}$
, which is
 $\varepsilon $
-close to f in the
 $C^1$
topology and
 $\tilde {g}\in \mathcal {X}_{\varphi }$
. This concludes the
 $C^1$
-density in this case.
If
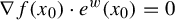 $\nabla f(x_0)\cdot e^w(x_0) = 0$
, consider first
 $n_0\in \mathbb {N}$
and a finite admissible word
 $b\in \mathbb {A}^{2n_0 + 1}$
such that the box
 $P(b)$
contains
 $x_0$
, but does not contain p. Set
 $$ \begin{align} L: = \sup_{x \in P(b)}|x\cdot e^w(x_0)|, N: = \sup_{x \in P(b)}\lVert\nabla f(x)\rVert \quad \text{and} \quad 0< \tau < \operatorname\min\{\varepsilon, \varepsilon/8L\}. \end{align} $$
Take
 $n\in \mathbb {N}$
,
 $n\geq n_0$
, and a finite admissible word
 $a\in \mathbb {A}^{2n+1}$
such that
 $P(a)\subset P(b)$
,
 $x_0\in P(a)$
and, for every
 $x\in P(a)$
,
 $$ \begin{align} |\nabla f(x) \cdot e^w_{x_0}| <\dfrac{\tau}{4}, \lVert e^w(x)-e^w(x_0)\rVert<\dfrac{\tau}{4(N+\tau)} \quad \text{and}\quad f(x)> f(x_0)-\dfrac{\varepsilon}{8}. \end{align} $$
Define
 $g:\Lambda \to \mathbb {R}$
by
 $$ \begin{align*} g(x) = \begin{cases} f(x) + \varepsilon/2 + \tau\, x\cdot e^w(x_0), & x\in P(a), \\ f(x), & x\in \Lambda\backslash P(a), \end{cases}\kern-3pt \end{align*} $$
and as before, extend g to a
 $C^1$
real function
 $\tilde {g}: M \to \mathbb {R}$
. Notice that, by (4.13) and (4.14),
 $\tilde {g} \in \mathcal {X}_{\varphi }$
. Indeed, for every
 $x\in P(a)$
,
 $$ \begin{align*} \tilde{g}(x) &= f(x)+\varepsilon/2 + \tau\, x\cdot e^w(x_0)> f(x_0) - \dfrac{\varepsilon}{8}+\dfrac{\varepsilon}{2}-\dfrac{\varepsilon}{8} \\&= f(x_0) + \dfrac{\varepsilon}{4} > \sup_{y \in \Lambda\backslash P(a)} \tilde{g}(y), \end{align*} $$
which proves condition (2). To see condition (3), notice that for every
 $x\in P(a)$
,
 $$ \begin{align*} \nabla \tilde{g}(x) \cdot e^w(x) & = (\nabla f(x) + \tau e^w(x_0))\cdot e^w(x)\\ &= \nabla f(x) \cdot e^w(x_0) + \tau + ( \nabla f(x)+ \tau e^w(x_0) )\cdot( e^w(x) - e^w(x_0) ) \\ &> -\dfrac{\tau}{4}+\tau - (\lVert\nabla f(x)\rVert+ \tau) \lVert e^w(x) - e^w(x_0)\rVert\\ &>\dfrac{3}{4}\tau -(N+\tau)\dfrac{\tau}{4(N+\tau)} =\dfrac{\tau}{2}. \end{align*} $$
Now, we see that
 $\tilde {g}$
is a
 $\varepsilon $
-perturbation of f in the
 $C^1$
-topology. For every
 $x\in P(a)$
,
 $$ \begin{align*} |f(x)-\tilde{g}(x)| &= |\varepsilon/2 + \tau\, x\cdot e^w(x_0)| < \varepsilon/2+\delta L < \varepsilon, \\ \lVert\nabla f(x)-\nabla \tilde{g}(x)\rVert &= \tau \lVert e^w(x_0)\rVert = \tau < \varepsilon. \end{align*} $$
Therefore,
 $\tilde {g}\in \mathcal {X}_{\varphi }$
is
 $\varepsilon $
-close to f, which finishes the proof of the density and the proposition.
4.5 Lower bound on the dimension of the Lagrange spectrum
Assume that
 $\operatorname {dim}(M)\geq 3$
. Let
 $\varphi \in \operatorname {Diff}^r(M)$
,
 $r\geq 2$
, be a diffeomorphism admitting a point
 $q_0$
with transversal homoclinic intersection associated with a
 $\varphi $
-periodic point
 $p\in M$
that we assume to be fixed. Additionally, assume that
 $\varphi $
satisfies conditions C1–C4 described in §4.1 with horseshoe
 $\Lambda $
.
Let
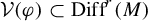 $\mathcal {V}(\varphi )\subset \operatorname {Diff}^r(M)$
be the
 $C^1$
-neighborhood of
 $\varphi $
described in §4.3. Let
 $(\sigma ,\Sigma )$
be the subshift of finite type coding every diffeomorphism in
 $\mathcal {V}(\varphi )$
(see [Reference Shub35]). Consider
 $\tilde {\varphi }\in \mathcal {V}(\varphi )$
and let
 $\Lambda (\tilde {\varphi })$
be the analytic continuation of
 $\Lambda $
for
 $\tilde {\varphi }$
.
Let
 $\mathcal {X}_{\tilde {\varphi }}$
be the subset constructed in §4.4 associated to the diffeomorphism
 $\tilde {\varphi }$
and the horseshoe
 $\Lambda (\tilde {\varphi })$
. Take
 $f\in \mathcal {X}_{\tilde {\varphi }}$
. So, there exist
 $n\in \mathbb {N}$
and a
 $\Lambda (\tilde {\varphi })$
-admissible word
 $a\in \mathbb {A}^{2n+1}$
such that:
-
(1)
$p\notin P(a)$
; -
(2)
$\inf _{x \in P(a)} f(x)> \sup _{x \in \Lambda (\tilde {\varphi }) \backslash P(a)}f(x)$
; -
(3)
$\inf _{x\in P(a)}|\nabla f(x)\cdot e^w(x)|> 0$
.

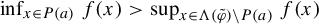
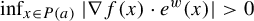
Recall the notation established in §§2.3.2 and 3. Consider the set
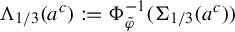 $\Lambda _{1/3}(a^c):= \Phi _{\tilde {\varphi }}^{-1}(\Sigma _{1/3}(a^c))$
. Since
 $\Lambda $
is conjugated to a subshift of finite type and
 $\varphi ^{N_0+n_0}|_{\Lambda _0}$
is conjugated to a full shift of two symbols
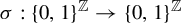 $\sigma :\{0,1\}^{\mathbb {Z}}\to \{0,1\}^{\mathbb {Z}}$
, by the conjugacy between the horseshoe
 $\Lambda (\tilde {\varphi })$
and
 $\Lambda $
, the same holds for
 $\Lambda (\tilde {\varphi })$
.
Consider
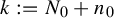 $k:=N_0 + n_0$
such that
 $k(2n+1)$
is odd. Applying Proposition 3.2, we see that for n sufficiently large,
 $\Lambda _{1/3}(a^c)$
is a transitive sub-horseshoe of
 $\Lambda (\tilde {\varphi })$
.
If b is a word of length
 $2n'+1$
, with
 $n'> n$
, such that
 $C_0(b)$
is a subset of
 $C_0(a)$
containing a maximal point of f on
 $\Lambda (\tilde {\varphi })$
, then the conditions (1)–(3) above are still satisfied when replacing a by b. Thus, we may take n as big as we want in the previous discussion.
Let
 $K^w(\tilde {\varphi }) \subset \Lambda _{1/3}(a^c)$
, given by Proposition 4.7.
Proposition 4.10. One has that
 $$ \begin{align*} \operatorname{dim}_H(L(\Lambda(\tilde{\varphi}), f)) \geq \operatorname{dim}_H(K^w(\tilde{\varphi}))> 0. \end{align*} $$
Proof. Define
 $g:= f\circ \Phi _{\tilde {\varphi }}^{-1}$
and observe that by condition (2) for f,
 $$ \begin{align*} \sup_{\Sigma\backslash C_{-n}(a)}\, g < \inf_{C_{-n}(a)}\, g. \end{align*} $$
Then, applying Proposition 3.4, there exists
 $j_0\in \mathbb {N}$
and an open subset
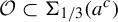 $\mathcal {O}\subset \Sigma _{1/3}(a^c)$
, such that
 $$ \begin{align} f\circ \tilde{\varphi}^{j_0} \circ \Phi_{\tilde{\varphi}}^{-1}\circ H_a(\mathcal{O}) = g\circ \sigma^{j_0}\circ H_a(\mathcal{O}) \subset L(\sigma,\, g) = L(\Lambda(\tilde{\varphi}),f). \end{align} $$
Moreover, for every
 $\theta \in \mathcal {O}$
,
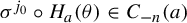 $\sigma ^{j_0}\circ H_a(\theta ) \in C_{-n}(a)$
. Set
 $$ \begin{align*} \hat{\mathcal{O}}:= \Phi_{\tilde{\varphi}}^{-1}(\mathcal{O}) \quad \text{and} \quad \hat{H} := \Phi_{\tilde{\varphi}}^{-1}\circ H_a \circ \Phi_{\tilde{\varphi}}:\Lambda(\tilde{\varphi})\to \Lambda(\tilde{\varphi}). \end{align*} $$
The sub-horseshoe
 $\Lambda _{1/3}(a^c)$
of
 $\Lambda (\tilde {\varphi })$
contains
 $\hat {\mathcal {O}}$
as an open subset and, by (4.15),
 $$ \begin{align} f\circ \tilde{\varphi}^{j_0}\circ \hat{H}(\hat{\mathcal{O}}) \subset L(\Lambda(\tilde{\varphi}),\, f). \end{align} $$
Take
 $x_0\in \hat {\mathcal {O}}$
and
 $\delta>0$
. By transitivity of
 $\Lambda _{1/3}(a^c)$
, we can find
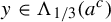 $y\in \Lambda _{1/3}(a^c)$
, such that
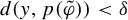 $d(y,p(\tilde {\varphi }))<\delta $
and
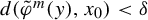 $d(\tilde {\varphi }^m(y), x_0)<\delta $
for some
 $m\in \mathbb {N}$
. We can assume that
 $\delta>0$
is small enough such that:
-
(i) the brackets
$z := [y,\, p(\tilde {\varphi })]$
,
$z_0 = [x_0, \, \tilde {\varphi }^m(z)]$
are well defined; -
(ii)
$W^s_{\tilde {\varphi },\delta }(z_0)\cap \Lambda _{1/3}(a^c) \subset \hat {\mathcal {O}}$
; -
(iii) the unstable holonomies
$H^u_{\tilde {\varphi },p(\tilde {\varphi }),z}: W^s_{\tilde {\varphi },\delta }(p(\tilde {\varphi }))\cap \Lambda _{1/3}(a^c)\to W^s_{\tilde {\varphi },\delta }(z)\cap \Lambda _{1/3}(a^c)$
and
$H^u_{\tilde {\varphi },\tilde {\varphi }^m(z), z_0}: W^s_{\tilde {\varphi },\delta }(\varphi ^m(z))\cap \Lambda _{1/3}(a^c)\to W^s_{\tilde {\varphi },\delta }(z_0)\cap \Lambda _{1/3}(a^c)$
are well defined.
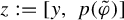
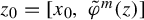
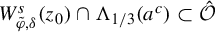
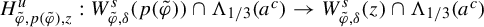
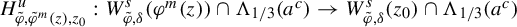
Consider the map
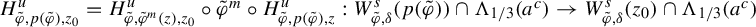 $H^u_{\tilde {\varphi },p(\tilde {\varphi }),z_0} = H^u_{\tilde {\varphi },\tilde {\varphi }^m(z),z_0}\circ \tilde {\varphi }^m\circ H^u_{\tilde {\varphi },p(\tilde {\varphi }),z}:W^s_{\tilde {\varphi },\delta }(p(\tilde {\varphi }))\cap \Lambda _{1/3} (a^c)\to W^s_{\tilde {\varphi }, \delta }(z_0)\cap \Lambda _{1/3}(a^c)$
and notice that by item (3) of Theorem 4.6, this is a
 $IC^{1+\alpha }$
map. Moreover, if we consider the compact set
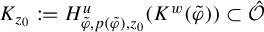 $K_{z_0} := H^u_{\tilde {\varphi },p(\tilde {\varphi }),z_0}(K^w(\tilde {\varphi })) \subset \hat {\mathcal {O}}$
, then
 $$ \begin{align*} IT_{z_0} K_{z_0} &= \Delta H^u_{\tilde{\varphi},p(\tilde{\varphi}),z_0}(p(\tilde{\varphi}),p(\tilde{\varphi})) \cdot IT_{p(\tilde{\varphi})} K^w(\tilde{\varphi})\\ &= \Delta H^u_{\tilde{\varphi},p(\tilde{\varphi}),z_0}(p(\tilde{\varphi}),p(\tilde{\varphi}))\cdot E^w_{\tilde{\varphi}}(p(\tilde{\varphi})) = E^w_{\tilde{\varphi}}(z_0). \end{align*} $$
Using Proposition 3.3 and (2.4), we see that there exists
 $k_0\in \mathbb {N}$
such that the map
 $\hat {H}$
, restricted to
 $W^s_{\tilde {\varphi },\delta }(z_0)\cap \Lambda _{1/3}(a^c)$
, can be written as
 $$ \begin{align} \hat{H} = \tilde{\varphi}^k\circ H^u_{\tilde{\varphi},z_0, \tilde{\varphi}^{-k}(\hat{H}(z_0))}: W^s_{\tilde{\varphi},\delta}(z_0)\cap \Lambda_{1/3}(a^c)\to W^s_{\tilde{\varphi},\delta_1}(\hat H(z_0))\cap \Lambda \end{align} $$
for some
 $\delta _1\in (0,\delta )$
and so, using again item (3) of Theorem 4.6, we see that
 $\hat {H}$
is
 $IC^{1+\alpha }$
. Hence, computing the intrinsic derivatives,
 $$ \begin{align*} \Delta (f\circ \tilde{\varphi}^{j_0}\circ \hat{H})(z_0,z_0)\cdot E^w_{\tilde{\varphi}}(z_0) &= \nabla f((\tilde{\varphi}^{j_0}\circ \hat{H})(z_0))\cdot \Delta(\tilde{\varphi}^{j_0}\circ \hat H)(z_0,z_0)\cdot E^w_{\tilde{\varphi}}(z_0)\\ &= \nabla f((\tilde{\varphi}^{j_0}\circ \hat{H})(z_0))\cdot E^w_{\tilde{\varphi}}(\tilde{\varphi}^{j_0}(\hat H(z_0)))\neq 0. \end{align*} $$
Here, it was used that
 $\tilde {\varphi }^{j_0}\circ \hat {H}(z_0)\in P(a)$
and condition (3) for f. Therefore, there is a small neighborhood of
 $z_0$
in
 $K_{z_0}$
such that the function
 $f\circ \tilde {\varphi }^{j_0}\circ \hat {H}$
restricted to this neighborhood is a Lipschitz invertible function with Lipschitz inverse. Now, using (4.16) and the fact that
 $K_{z_0}$
has positive Hausdorff dimension, we conclude that
 $$ \begin{align*} \operatorname{dim}_H\, L(\Lambda(\tilde{\varphi}), f) \geq \operatorname{dim}_H( f\circ \tilde{\varphi}^{j_0}\circ \hat H(K_{z_0}) ) = \operatorname{dim}_H(K^w(\tilde{\varphi}))> 0. \end{align*} $$
This finishes the proof of the proposition.
5 Proof of the results
In this section, we give proofs for the main results of this work, namely Theorems A, B and C.
5.1 Proof of Theorem C
Consider now
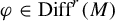 $\varphi \in \operatorname {Diff}^r(M)$
,
 $r\geq 2$
, admitting a point of transversal homoclinic intersection
 $q_0\in M$
associated with a
 $\varphi $
-periodic point
 $p\in M$
. We assume without loss of generality that p is fixed.
By Proposition 4.2, we can find
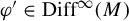 $\varphi '\in \operatorname {Diff}^{\infty }(M)$
,
 $C^r$
-close to
 $\varphi $
, satisfying conditions C1–C4. Let
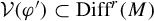 $\mathcal {V}(\varphi ') \subset \operatorname {Diff}^r(M)$
be the open
 $C^1$
-neighborhood of
 $\varphi '$
discussed in §4.5. Take
 $\tilde {\varphi }\in \mathcal {V}(\varphi ')$
. By Proposition 4.9, the set
 $\mathcal {X}_{\tilde {\varphi }}$
is open and dense in
 $C^1(M;\, \mathbb {R})$
. Therefore, for any
 $f\in \mathcal {X}_{\tilde {\varphi }}$
, we can use Proposition 4.10 to conclude that
 $$ \begin{align*} \operatorname{dim}_H(M(\tilde{\varphi},\, f)) \geq \operatorname{dim}_H(L(\tilde{\varphi},\, f)) \geq \operatorname{dim}_H(K^w(\tilde{\varphi}))> 0. \end{align*} $$
This finishes the proof of Theorem C.
Remark 5.1. When M is a two-dimensional manifold, any
 $C^2$
diffeomorphism
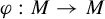 $\varphi :M\to M$
admitting a horseshoe
 $\Lambda $
has
 $IC^{1+\gamma }$
holonomies (see [Reference Palis and Viana28, Remark 3.7]). This ensures that the stable/unstable Cantor sets at points of the horseshoe have a regular Cantor set structure. Applying the previous reasoning, this is enough to guarantee the existence of a
 $C^1$
-open neighborhood
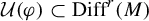 $\mathcal {U}(\varphi )\subset \operatorname {Diff}^r(M)$
of
 $\varphi $
,
 $r\geq 2$
, such that for any
 $\tilde {\varphi }\in \mathcal {U}(\varphi )$
, we have
 $$ \begin{align*} \operatorname{dim}_H(M(\tilde{\varphi},\, f)) \geq \operatorname{dim}_H(L(\tilde{\varphi},\, f)) \geq \operatorname{dim}_H(K_{\tilde{p}}(\tilde{\varphi}))> 0, \end{align*} $$
where
 $K_{\tilde {p}}(\tilde {\varphi })$
is the stable Cantor set at
 $\tilde {p}$
. This result was first established in [Reference Romaña Ibarra and de A. Moreira33].
Remark 5.2. The assumption
 $r\geq 2$
is essential to ensure the regularity of the unstable holonomies for diffeomorphisms
 $C^1$
-close to
 $\varphi $
. We believe that a new strategy is required to explore the case
 $r = 1$
due to limitations that the lack of regularity of the holonomies imposes.
5.2 Proof of Theorem B
Let
 $\varphi _0$
be a Morse–Smale diffeomorphism in
 $\mathrm {{Diff}}^1(M)$
and let
 $S_0$
be an attracting fixed point for
 $\varphi _0$
. Consider an open neighborhood V of
 $S_0$
satisfying that
 $U:=\overline {V}$
is a compact subset of
 $W^s_{\mathrm {loc}}(S_0)$
and
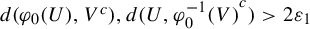 for some
 $\varepsilon _1>0$
.
Given a point
 $x_0$
in
 $V\backslash \varphi _0(U)$
, consider an open neighborhood W of
 $x_0$
such that
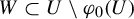 $W \subset U\setminus \varphi _0(U)$
and
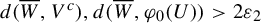 $d(\overline {W}, V^c), d(\overline {W}, {\varphi _0(U)})> 2\varepsilon _2$
for some
 $\varepsilon _2>0$
. Let
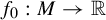 $f_0: M \to \mathbb {R}$
be a real function, satisfying
 $$ \begin{align*}f_0(x_0)>0, \; {\nabla f_0(x_0)}\neq 0 \quad \text{and} \quad \textrm{supp}(f_0)\subset W.\end{align*} $$
Since the set of Morse–Smale diffeomorphisms is structurally stable, we can consider
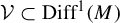 $\mathcal {V} \subset \operatorname {Diff}^1(M)$
a
 $C^1$
-neighborhood of
 $\varphi _0$
, such that for every
 $\varphi \in \mathcal {V}$
, the following conditions hold:
-
(i)
$\varphi $
is a Morse–Smale diffeomorphism; -
(ii)
$d(\varphi (U), V^c), d(U, {\varphi ^{-1}(V)}^c)> \varepsilon _1 $
; -
(iii)
$d(\overline {W}, {\varphi (U)})> \varepsilon _2$
.

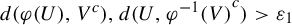

Let
 $\mathcal {W} \subset C^1(M; \mathbb {R})$
be a neighborhood of
 $f_0$
, such that for every
 $f \in \mathcal {W}$
,
 $$ \begin{align} f(x_0)>f_0(x_0)/2, \; \;{\nabla f(x_0)}\neq 0 \quad \text{and} \quad |f(x)|<f_0(x_0)/4\quad \textrm{for every } x \notin W. \end{align} $$
Define
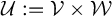 $\mathcal {U}:=\mathcal {V}\times \mathcal {W}$
. Note that for every
 $(\varphi , f) \in \mathcal {U}$
,
 $x \in W$
, and every positive integer n, by condition (iii), we have
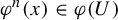 $\varphi ^n(x) \in \varphi (U)$
and
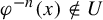 $\varphi ^{-n}(x) \notin U$
.
Since
 $\varphi (U)\cap W = \emptyset $
and
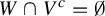 $W \cap V^c=\emptyset $
, using (5.1), we obtain that
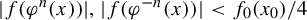 $|f(\varphi ^n(x))|, |f(\varphi ^{-n} (x))|<f_0(x_0)/4$
. Thus, for a small neighborhood O of
 $x_0$
, where the values in
 $f(O)$
are greater than
 $f_0(x_0)/4$
, we have
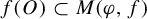 $f(O)\subset M(\varphi , f)$
. The condition
 $\nabla f(x_0) \neq 0$
, together with the inverse function theorem, is enough to ensure that
 $f({O})$
contains an interval.
Therefore, for every
 $(\varphi ,\, f) \in \mathcal {U}$
, the Markov spectrum
 $M(\varphi ,\, f)$
has non-empty interior and the Lagrange spectrum
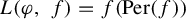 $L(\varphi ,\, f) = f(\operatorname {Per}(f))$
is finite.
5.3 Proof of Theorem A
Assume first that
 $\operatorname {dim} M \geq 2$
. Denote by
 $\mathcal {M}\mathcal {S}(M)$
the set of Morse–Smale diffeomorphisms in
 $\operatorname {Diff}^2(M)$
and by
 $\mathcal {H}(M)$
the subset of
 $C^{2}$
diffeomorphisms, which presents a transverse homoclinic intersection. Notice that
 $\mathcal {M}\mathcal {S}(M)$
and
 $\mathcal {H}(M)$
are
 $C^1$
-open, disjoint subsets of
 $\operatorname {Diff}^2(M)$
and the union of these sets, by [Reference Crovisier9], is
 $C^1$
-dense in
 $\operatorname {Diff}^{2}(M)$
.
For each diffeomorphism
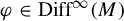 $\varphi \in \operatorname {Diff}^{\infty }(M)$
satisfying conditions C1–C4, consider the open set
 $\mathcal {V}(\varphi )$
given by §4.3 (see also §4.5). Denote by
 $\mathcal {C}(M)$
the subset of
 $\operatorname {Diff}^2(M)$
consisting of the union of the open sets
 $\mathcal {V}(\varphi )$
for smooth diffeomorphisms
 $\varphi $
satisfying conditions C1–C4. By Proposition 4.2, this is a
 $C^1$
-open and
 $C^2$
-dense subset of
 $\operatorname {Diff}^2(M)$
.
Define
 $$ \begin{align*} \mathcal{D}(M) := \{ (\varphi,\, f)\in \operatorname{Diff}^2(M)\times C^1(M;\, \mathbb{R})\colon\, \varphi\in \mathcal{C}(M),\, f\in \mathcal{X}_{\varphi} \}, \end{align*} $$
and consider the data set
 $$ \begin{align*} \mathcal{R}(M) := \mathcal{D}(M)\cup (\mathcal{M}\mathcal{S}(M)\times C^1(M;\, \mathbb{R})). \end{align*} $$
Take
 $(\varphi , f) \in \mathcal {R}(M)$
. In the case that
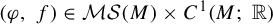 $(\varphi ,\, f)\in \mathcal {M}\mathcal {S}(M)\times C^1(M;\, \mathbb {R})$
,
 $\varphi $
is Morse–Smale and this ensures the finiteness of
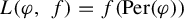 $L(\varphi ,\, f) = f(\operatorname {Per}(\varphi ))$
. If
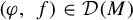 $(\varphi ,\, f)\in \mathcal {D}(M)$
, then, as a consequence of the proof of Theorem C (and Remark 5.1), we see that
 $L(\varphi ,\, f)$
has positive Hausdorff dimension. Since
 $\varphi \in \mathcal {C}(M)$
has an associated horseshoe, we have
 $h_{\text {top}}(\varphi )>0$
.
We claim that
 $\mathcal {R}(M)$
is
 $C^1$
-open and
 $C^2$
-dense in
 $\operatorname {Diff}^2(M)$
. First, we deal with the density. Take
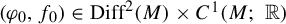 $(\varphi _0,f_0)\in \operatorname {Diff}^2(M)\times C^1(M;\, \mathbb {R})$
. As mentioned before, we can find
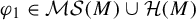 $\varphi _1\in \mathcal {M}\mathcal {S}(M)\cup \mathcal {H}(M)$
, which is
 $C^1$
-close to
 $\varphi _0$
(see [Reference Crovisier9]). If
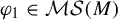 $\varphi _1\in \mathcal {M}\mathcal {S}(M)$
, then
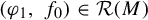 $(\varphi _1,\,f_0) \in \mathcal {R}(M)$
. Otherwise, if
 $\varphi _1\in \mathcal {H}(M)$
, then there exists
 $\varphi _2 \in \mathcal {C}(M)$
, which is
 $C^2$
-close to
 $\varphi _1$
. By Proposition 4.9, we can find
 $f_1\in \mathcal {X}_{\varphi _2}$
, which is
 $C^1$
-close to
 $f_0$
. Then, the pair
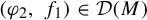 $(\varphi _2,\, f_1)\in \mathcal {D}(M)$
is
 $C^1$
-close to
 $(\varphi _0,\, f_0)$
and this finishes the proof of the density.
Now, we prove that
 $\mathcal {R}(M)$
is open. Using the fact that
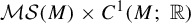 $\mathcal {M}\mathcal {S}(M)\times C^1(M;\, \mathbb {R})$
is open, it is enough to prove that
 $\mathcal {D}(M)$
is
 $C^1$
-open. For that, take
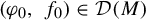 $(\varphi _0,\, f_0)\in \mathcal {D}(M)$
.
Choose
 $\delta _0>0$
small such that for any
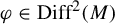 $\varphi \in \operatorname {Diff}^2(M)$
with
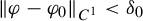 $\lVert \varphi - \varphi _0\rVert _{C^1}<\delta _0$
, the analytic continuation
 $\Lambda (\varphi )$
of
 $\Lambda (\varphi _0)$
for
 $\varphi $
is well defined, and the conjugacy map
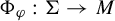 $\Phi _{\varphi }:\Sigma \to M$
between
 $(\sigma ,\, \Sigma )$
and
 $(\varphi ,\, \Lambda (\varphi ))$
depends continuously on
 $\varphi $
in this ball. Moreover (see [Reference Shub35, Theorem 8.3]), there exists
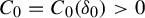 $C_0 = C_0(\delta _0)>0$
such that
 $$ \begin{align} \sup_{\theta\in \Sigma}\, d(\Phi_{\varphi}(\theta), \Phi_{\varphi_0}(\theta)) \leq C_0\, \lVert\varphi - \varphi_0\rVert_{C^1}. \end{align} $$
Decreasing
 $\delta _0$
and taking a small compact neighborhood U of
 $\Lambda (\varphi _0)$
, we can assume that the map associating each
 $x\in \Lambda (\varphi )$
in the weak stable direction
 $E^w_{\varphi }(x)$
has an extension to U satisfying that for every
 $x, y \in U$
:
-
(1) there exists
$C_1>0$
such that (5.3)
$$ \begin{align} d(E^w_{\varphi}(x),\, E^w_{\varphi_0}(x)) < C_1\, \lVert\varphi - \varphi_0\rVert_{C^1}; \end{align} $$
-
(2) there exist uniform constants (independent of
$\varphi $
),
$M>0$
and
$\gamma _0\in (0,1)$
, such that (5.4)
$$ \begin{align} d(E^w_{\varphi}(x),\, E^w_{\varphi}(y)) \leq M\, d(x,\,y)^{\gamma_0}. \end{align} $$


The first item is found in [Reference Crovisier and Potrie10, Corollary 2.8]. For the second item, we refer to [Reference Brin and Pesin6, Corollary 2.1] and [Reference Crovisier and Potrie10, Theorem 4.11].
Since
 $f_0\in \mathcal {X}_{\varphi _0}$
, we can find
 $\varepsilon>0$
,
 $n\in \mathbb {N}$
, and a finite
 $\Lambda (\varphi _0)$
-admissible word
 $a\in \mathbb {A}^{2n+1}$
such that
 $$ \begin{align} \sup_{\Lambda(\varphi_0)\backslash \Phi_{\varphi_0}(C_{-n}(a))}\kern-2pt f_0 + \varepsilon < \inf_{\Phi_{\varphi_0}(C_{-n}(a))}\kern-2pt f_0 - \varepsilon \quad \text{and} \quad \inf_{x\in \Phi_{\varphi_0}(C_{-n}(a))}\kern-2pt|\nabla f_0(x)\cdot e^w_{\varphi_0}(x)| \geq \varepsilon, \end{align} $$
where
 $e^w_{\varphi _0}(x)$
denotes a unitary direction inside of
 $E^w_{\varphi _0}(x)$
. Take
 $L := \sup _{\lVert f - f_0\rVert _{C^1}\leq \delta _0} \lVert \nabla f\rVert _{\infty }$
and consider
 $\delta _1\in (0,\delta _0)$
such that
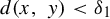 $d(x,\, y)<\delta _1$
implies that
 $$ \begin{align} \lVert\nabla f_0(x) - \nabla f_0(y)\rVert < \varepsilon/8, \end{align} $$
and consider
 $$ \begin{align*} \delta = \operatorname\min\bigg\{ \delta_1,\, \bigg( \frac{\varepsilon}{8ML} \bigg)^{1/\gamma_0}\, 1/C_0,\, \varepsilon/8,\, \frac{\varepsilon}{8LC_1},\, \frac{\varepsilon}{1 + L\, C_0}, \dfrac{\delta_1}{C_0} \bigg\}. \end{align*} $$
Now, consider
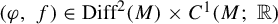 $(\varphi ,\, f)\in \operatorname {Diff}^{2}(M)\times C^1(M;\, \mathbb {R})$
with
 $$ \begin{align} \lVert\varphi - \varphi_0\rVert_{C^1} <\delta \quad \text{and} \quad \lVert f - f_0\rVert_{C^1} < \delta. \end{align} $$
Then, using inequalities (5.2) and (5.7), for every
 $\theta \in \Sigma $
,
 $$ \begin{align} | f(\Phi_{\varphi}(\theta)) - f_0(\Phi_{\varphi_0}(\theta)) | &\leq | f(\Phi_{\varphi}(\theta)) - f(\Phi_{\varphi_0}(\theta)) | + | f(\Phi_{\varphi_0}(\theta)) - f_0(\Phi_{\varphi_0}(\theta)) |\nonumber\\ &\leq \lVert\nabla f\rVert\, d(\Phi_{\varphi}(\theta),\, \Phi_{\varphi_0}(\theta)) + \lVert f - f_0\rVert_{C^1}\nonumber\\ &\leq L\, C_0\, \delta + \delta \leq \varepsilon. \end{align} $$
Furthermore, if we denote by
 $x := \Phi _{\varphi }(\theta )$
and
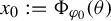 $x_0 := \Phi _{\varphi _0}(\theta )$
, then using the triangular inequality, inequalities (5.2), (5.3), (5.4), and (5.7), and by the choice of parameter
 $\delta $
, we have
 $$ \begin{align} &| \nabla f(x)\cdot e^w_{\varphi}(x) \kern1.4pt{-}\kern1.4pt \nabla f_0(x_0)\cdot e^w_{\varphi_0}(x_0) | \kern1.4pt{\leq}\kern1.4pt \lVert\nabla f\rVert_{\infty}\, d(e^w_{\varphi}(x),\, e^w_{\varphi}(x_0)) \kern1.4pt{+}\kern1.4pt \lVert\nabla f(x) \kern1.4pt{-}\kern1.4pt \nabla f_0 (x)\rVert\nonumber\\ &\qquad+ \lVert\nabla f_0(x) - \nabla f_0(x_0)\rVert + \lVert\nabla f_0\rVert_{\infty}\, d(e^w_{\varphi}(x_0),\, e^w_{\varphi_0}(x_0))\nonumber\\ &\quad\leq L\, M\, d(x,\, x_0)^{\gamma_0} + \delta + \varepsilon/8 + L\, C_1\, \lVert\varphi-\varphi_0\rVert_{C^1}\nonumber\\ &\quad\leq L\, M\, (C_0\, \delta)^{\gamma_0} + \varepsilon/4 + L\, C_1\, \delta \leq \varepsilon/2. \end{align} $$
Now, we are in a position to check the requirements needed to guarantee that
 $f\in \mathcal {X}_{\varphi }$
. Indeed, using inequality (5.8), we see that if
 $\theta \notin C_{-n}(a)$
, then
 $$ \begin{align*} f(\Phi_{\varphi}(\theta)) \leq f_0(\Phi_{\varphi_0}(\theta)) + \varepsilon \leq \sup_{\Lambda(\varphi_0)\backslash \Phi_{\varphi_0}(C_{-n}(a))}\, f_0 + \varepsilon, \end{align*} $$
and if
 $\theta \in C_{-n}(a)$
,
 $$ \begin{align*} f(\Phi_{\varphi}(\theta)) \geq f_0(\Phi_{\varphi_0}(\theta)) - \varepsilon \geq \inf_{\Phi_{\varphi_0}(C_{-n}(a))}\, f_0 - \varepsilon. \end{align*} $$
Then, by (5.5), we have
 $$ \begin{align*} \sup_{\Lambda(\varphi)\backslash \Phi_{\varphi}(C_{-n}(a))}\, f \leq \sup_{\Lambda(\varphi_0)\backslash \Phi_{\varphi_0}(C_{-n}(a))}\, f_0 + \varepsilon < \inf_{\Phi_{\varphi_0}(C_{-n}(a))}\, f_0 - \varepsilon \leq \inf_{\Phi_{\varphi}(C_{-n}(a))}\, f. \end{align*} $$
The second condition in the definition of
 $\mathcal {X}_{\varphi }$
can be checked similarly as follows: by (5.5) and (5.9), for any
 $\theta \in C_{-n}(a)$
,
 $$ \begin{align*} | \nabla f(\Phi_{\varphi}(\theta))\cdot e^w_{\varphi}(\Phi_{\varphi}(\theta)) | \geq | \nabla f_0(\Phi_{\varphi_0}(\theta))\cdot e^w_{\varphi_0}(\Phi_{\varphi_0}(\theta)) | - \varepsilon/2 \geq \varepsilon/2> 0. \end{align*} $$
Therefore,
 $f\in \mathcal {X}_{\varphi }$
and so this shows that any pair
 $(\varphi , f)$
satisfying (5.7) belongs to
 $\mathcal {D}(M)$
proving that
 $\mathcal {D}(M)$
is
 $C^1$
-open in
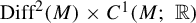 $\operatorname {Diff}^{2}(M)\times C^1(M;\, \mathbb {R})$
.
It remains to analyze the case where
 $\operatorname {dim} M = 1$
. However, for circle diffeomorphisms, it is known that the set of Morse–Smale diffeomorphisms is an open and dense in
 $\operatorname {Diff}^1_+(M)$
(see [Reference Devaney12, §1.15]). Therefore, for any
 $f\in C^0(M;\, \mathbb {R})$
, we have that
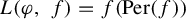 $L(\varphi ,\, f) = f(\operatorname {Per}(f))$
is finite. This concludes the proof of Theorem A.
Acknowledgements
This research was partially supported by the Narodowe Centrum Nauki Grant 2022/45/B/ST1/00179, by the Center of Excellence ‘Dynamics, Mathematical Analysis and Artificial Intelligence’ at Nicolaus Copernicus University in Toruń, by FCT-Fundação para a Ciência e a Tecnologia through the project PTDC/MAT-PUR/29126/2017, and by CNPq, through the project 408587/2023-7 on the Chamada Universal 10/2023. We would like to thank Davi Lima and Sergio Romaña for their careful reading and helpful suggestions in the early stages of the manuscript.