1.0 INTRODUCTION
Composites are widely used in aviation industry due to their advantages(Reference Van Tooren, Kasapoglou and Bersee1,Reference Cheng2) such as high specific stiffness, high specific strength and designability, so using composites is an effective way to achieve weight loss and reduce aircraft operating costs(Reference Niemann3). Anisotropic composites are multifarious in the structure form and have inhomogeneity on the micro structure. Also, the aircraft will experience all kinds of loads in service process. The composite structures and components are usually impacted by low-velocity objects (e.g. a tool drops in the manufacture or maintenance process; run debris; hail)(Reference Shipsha, Hallström and Zenkert4). These impacts can lead to significant subsurface damages(Reference Shipsha, Hallström and Zenkert4,Reference Ji and Waas5) such as delaminations, matrix cracks, fibre breaks and so on. These damages may grow to a critical size that will result in the catastrophic fracture of the composite structures and/or components(Reference Banerjee6). The structural health monitoring techniques have been investigated widely to improve the safety and lifetime of composite structures and components and to reduce the cost of operation and maintenance(Reference Roy7). The precise identification of the impact location and impact loads (such as force and energy) is important for the localisation and quantification of the damage, which is vital to further investigation of the remaining life of damaged structures for aircraft structural health.
The impact identification problem is difficult to solve because it is an inverse problem. There are two issues surrounding this impact identification problem: how to locate the impact events, and estimating the impact force or impact energy. If the impact location is confirmed accurately on the composite structure, it is helpful to examine the important zone quickly and estimate the damage severity as early as possible. The impact force and energy identification is significant for analysing the impact damage and predicting the remaining life of damaged structures. The oldest method of finding the impact point was based on the distance between the impact location and sensors, the velocity of the stress wave and the arrival-time of different signals. This kind of approach has been applied to the acoustic emission technique for many years(Reference Tobias8). Gaul(Reference Gaul and Hurlebaus9) and Liang(Reference Liang, Yuan and Liu10) used the wavelet transform to get the arrival time of the stress wave on different frequencies and then estimate the impact location based on the distance, the wave velocity and the arrival time. There are many signal processing methods(Reference Ding, Reuben and Steel11) to extract the arrival time or the speed of the stress wave. However, it is hard to get the accurate arrival time and the velocity, especially for complex structures with joints and stiffeners. Significant efforts have been made to determine the impact location on composite structures(Reference Worden and Staszewski12−Reference Sharif-Khodaei, Ghajari and Aliabadi15). The optimisation algorithm (such as the genetic algorithm(Reference Worden and Staszewski12)) is usually introduced into the impact location identification method(Reference Martin and Doyle16) so as to get better recognition accuracy. Park(Reference Park, Ha and Chang14,Reference Park and Chang17) proposed a method based on the power distribution of the sensor network to estimate the impact location, but this method needs many sensors. The neural network method was also used to identify the impact location by Haywood(Reference Haywood13). Mujica(Reference Mujica18) used a knowledge-based reasoning method to estimate the impact location on complex structures, but this requires a lot of training data and effective signal extraction technology. Qiu(Reference Qiu19) used wavelet transform to extract the phase velocity of the signals and applied the time reversal focusing technology to determine the impact location on a stiffened composite plate, and the velocities in all directions were replaced by the average phase velocity. Yuan(Reference Yuan20) proposed a near-field multiple signal classification-based impact localisation method, noting that the velocity of the signal should be used in the method. Wu(Reference Wu21) used basis vectors to identify the impact location and impact energy on composite plate. The basis-vector-based method is widely used in other areas of research, such as the matching pursuit method(Reference Kubo22), building the fuzzy model(Reference Fan23), the least squares support vector machine(Reference Lv, Jiang and Li24), the location determination in the communications(Reference Liu and Lin25) and so on. Chang(Reference Chang and Sun26) reconstructed the impact time history on a composite structure using experimentally generated Green's functions and signal deconvolutions. Wu(Reference Wu, Yeh and Yen27,Reference Ching-Shih and Enboa28) utilised the optimisation method to reconstruct the impact force time history. The governing equations of the plate were obtained by applying the Reissner-Mindlin plate theory and the Rayleigh-Ritz method(Reference Ching-Shih and Enboa28). The force history was subsequently determined after the impact location was identified. The conjugate gradient method was adopted to search for the optimal impact location as well as the force history. Shin(Reference Shin29) proposed a compact and systematic scheme for the real-time recovery of force and location during impact events based on finite element analysis. Hu(Reference Hu30) employed a Chebyshev polynomial to approximate the impact force time history. The parameters in the Chebyshev polynomial and the strain response were formulated through the finite element method and the mode superposition method. By comparing the estimated strains and the experimental strains, the force time history was identified. Akhavan(Reference Akhavan, Watkins and Chandrashekhara31) used neural networks to obtain impact force time history on composite plates by fiber optic sensors. However, a lot of training data of impact test is needed, and there is a high computational cost and poor universality. Gaul(Reference Gaul and Hurlebaus32) and Peelamedu(Reference Peelamedu, Ciocanel and Naganathan33) formulated the relationship of the outputs of sensors and the impact force to estimate the impact force on the isotropic plate, but it may be difficult to get such a relationship for anisotropic composite structures. Park(Reference Park, Ha and Chang14) presented an inverse method based on a system identification technique to reconstruct force time history of an impact event on a complex structure. This method requires neither construction of a full-scale accurate structural model nor acquisition of excessive training data on the structure. Chen and Yuan(Reference Chen and Yuan34,Reference Chen, Li and Yuan35) identified the impact location and impact force time history in finite isotropic plate-like structures based on the time reversal method and verified the feasibility of this method by numerical simulation and experiments, respectively.
We know that the precise localisation and impact load estimation is the key for locating the damage and analysing the damage severity for the security and stability of aircraft structures. Therefore, an impact identification algorithm is solved in a hybrid strategy in this study. The proposed hybrid strategy is made up of two stages. The first stage is to locate the impact event using the proposed basis vector. The second stage is to reconstruct the impact force history using the transfer function of system identification in the literature(Reference Park, Ha and Chang14). The contribution of this study is to present an impact location method based on a basis vector using a small number of sensors compared to previous work, while the dimension of the transfer function is reduced using the first half pulse of the impact force. The idea of the basis vector is derived from case-based reasoning. The advantages of the proposed method are that it requires a small number of sensors (only four sensors in this study) and the basis vector is easy to construct without extracting the precise velocity of the wave for localisation. The information of the wave signal of the impact source is extracted to construct the basis vector to estimate the impact location, and the relationship between the signal and impact force is built by a simplified transfer function to reconstruct the impact force. A validated experiment is performed on a flat glass fibre-epoxy matrix composite plate using only four piezoelectric sensors. Moreover, the soft impactor and hard impactor are two typical impactors in impact events, so the correlation coefficient is used to choose the corrected transfer function according to the impactor. Finally, the impact identification results on the composite plate are reported and the conclusions of the presented algorithm are summarised.
2.0 IMPACT IDENTIFICATION ALGORITHM
In this section, the impact identification algorithm based on basis vectors and transfer functions is proposed and described in detail. As for the impact localisation, the stress wave in a thin plate structure is a kind of Lamb wave(Reference Qiu19,Reference Lamb36) which has multiple modes and dispersion characteristics, and the complexity of the Lamb wave makes it hard to estimate the location of the impact force. The localisation method based on basis vectors utilises the features of the impact source to estimate the impact position. The features of the impact source are obtained by sensor signals from piezoelectric sensors which have broad frequency bandwidth, low cost and other advantages(Reference Park37). As for the impact force reconstruction, the inverse non-linear problem makes it difficult to get the impact force. Compared with the method based on the model of the structure and the method based on the finite element analysis, the method based on the transfer function between the impact force and the sensor signal is widely used to quickly and effectively identify the impact force(Reference Park, Ha and Chang14,Reference Chen and Yuan34,Reference Chen, Li and Yuan35) . Therefore, the transfer function is employed and developed to identify the impact force time history in this paper.
The transfer functions are obtained by a calibration procedure, but information about the impact position of the calibration points is usually ignored in the calibration process. That is to say, the basis vector of each calibration point can be acquired simultaneously. The steps of the algorithm of the impact identification are shown as follows to estimate the impact location and identify the impact force time history.
a) In order to build the relationship of the input and output, it is necessary to perform a calibration procedure first. Through the recording input (impact force and location) and output (response signal), the basis vectors and transfer functions can be obtained simultaneously for a few sparse calibration points, and this process can be carried out either experimentally or numerically. In this paper, a real experiment is performed to get the calibration data. The basis vector and the transfer function of each calibration point are obtained in this process.
b) When an impact event occurs, the sensor array installed in the plate will acquire the sensor signals from the impact source. The features of the signals are extracted for the basis vector and the transfer functions by signal processing.
c) The initial position of the impact force is estimated by the basis vector method, and the force time history is reconstructed by the transfer function of the estimated position.
d) At the last step of the impact identification algorithm, according to an initial estimation, the impact location and the impact force are updated to find the minimal error of reconstructed forces from multiple sensors in order to identify more accurate impact location and force time history.
The algorithm of the impact identification can be incorporated into the real-time impact monitoring system. The focus of this paper is to verify the feasibility of the proposed impact identification algorithm, and two different impactors are included for the impact test on a composite plate structure to identify the algorithm.
2.1 Localisation method
The basis vector is defined as a matrix to represent the relationship between the impact point location and the sensor signals of the structure. The basis vector may include some state parameters about the arrival time of the stress wave, the power of the sensor signal, the amplitude of the sensor signal and so on. For simplicity, the basis vector includes only the state parameter of the power of the sensor signal in this paper. When impacts occur on different locations of the plate, the stress wave distributions obtained by sensors on different locations are not alike. It is assumed that the boundary conditions and the geometry conditions are constant and the intercept time of signals is fixed while the power of signals from the sensor array is different. Only four sensors are used as an array in this paper. The impact position and the matrix of signal power of sensors have a one-to-one mapping relationship.
For a given signal s(t), the root-mean-square (rms) power of the signal is defined for a given time window as follows:
 $$\begin{equation}
P = \sqrt {\frac{1}{{{t_n} - {t_0}}}\int_{{t_0}}^{{t_n}} {|s(t){|^2}} {\rm{d}}t} ,
\end{equation}$$
where t 0 is the initial time and tn is the terminal time. The time t 0 is defined as the first time at which the signal crosses a threshold value (0.02V in this paper). In this paper, rms power is used to obtain the power of the sensor signal. For the calculation of the signal power, the truncation time is about 6.5ms, which is the whole length of the signal, and the initial time and terminal time for all sensors are chosen according to sensor 1. The basis vector of four signal power at a given impact location is defined as follows:
 $$\begin{equation}
\xi \left( {x,y} \right) = [\bar P{s_1},\bar P{s_2},\bar P{s_3},\bar P{s_4}],
\end{equation}$$
where ξ(x, y) is normalised and stands for the basis vector at impact position (x, y), and  $\bar P{s_1}$,
 $\bar P{s_2}$,
 $\bar P{s_3}$,
 $\bar P{s_4}$ represent normalised signal power of the four sensors, respectively, and the normalised method is given in Equation (2.3). Therefore, the basis vector can be built to describe the relationship of the impact point location and the sensor signals of the structure.
 $$\begin{equation}
{\overline P _{{s_i}}} = \frac{{{P_{{s_i}}}}}{{\sqrt {\sum\limits_{i = 1}^4 {{{\left( {{P_{{s_i}}}} \right)}^2}} } }}
\end{equation}$$
A basis vector method is proposed to estimate the impact location. The flow chart of the basis vector method is shown in Fig. 1. The first step is to search for the cell in which the impact is located, and the second step is to estimate the impact location by a centre-of-gravity method in this cell. First of all, the basis vector of each calibration point within the monitoring area is obtained by experiment or finite element method, as shown in Fig. 2. When an impact event occurs on the structure, the four sensors on the structure will acquire the response signals. The signal power of four sensors constitutes a power vector of sensor signals at any impact location, and the basis vector of the current impact location can be obtained by normalising the power vector of the sensor signals. Secondly, the basis vector of the current impact event is compared with the basis vectors of calibration points one by one to obtain the error at each calibration point. Each small cell or element has four calibration points, and the error of each cell is the average of the errors at the four calibration points. The cell with the smallest error is chosen as the impact cell. The matrix composed of basis vector at each calibration point is shown as follows, where i is the number at each calibration point.
 $$\begin{equation}
{\xi _{{\rm{basic}}}} = {\left[{{\xi _1}\left( {{x_1},{y_1}} \right),{\xi _2}\left( {{x_2},{y_2}} \right),{\xi _i}\left( {{x_i},{y_i}} \right), \ldots {\xi _n}\left( {{x_n},{y_n}} \right)} \right]^T}\quad \left( {i = 1,2,3, \ldots n} \right)
\end{equation}$$
The flowchart of the basis vector method.

The construction of basis vectors.
The basis vector of the current impact event:
 $$\begin{equation}
{\xi _*}\left( {{x_*},{y_*}} \right) = [{\bar P_ * }{s_1},{\bar P_ * }{s_2},{\bar P_ * }{s_3},{\bar P_ * }{s_4}]
\end{equation}$$
By comparing the basis vector of the current impact event and the basis vector of the ith calibration point, the component error of these two vectors is written as:
 $$\begin{equation}
{\delta _{i,k}} = \left[{\left| {\frac{{{\xi _{i,k}}\left( {{x_*},{y_*}} \right) - {\xi _{i,k}}\left( {{x_i},{y_i}} \right)}}{{{\xi _{i,k}}\left( {{x_i},{y_i}} \right)}}} \right|} \right]\quad \left( {i = 1,2,3, \ldots n,k = 1,2,3,4} \right),
\end{equation}$$
where k is the number of the sensor. The error between any calibration point and the current impact location is defined as the sum of the component error.
 $$\begin{equation}
{\delta _i} = \sum\limits_{k = 1}^4 {{\delta _{i,k}}}
\end{equation}$$
Assuming that the number vector of calibration points in each cell is shown as:
 $$\begin{equation}
{\rm{Ne}}{{\rm{t}}_j} = [{n_{j1}},{n_{j2}},{n_{j3}},{n_{j4}}],
\end{equation}$$
where n is the number of the calibration point in the cell, and j is the number of the cell. Then the error vector of each cell is defined as:
 $$\begin{equation}
{\Delta _{{\rm{Ne}}{{\rm{t}}_j}}} = [{\delta _{{n_{j1}}}},{\delta _{{n_{j2}}}},{\delta _{{n_{j3}}}},{\delta _{{n_{j4}}}}]
\end{equation}$$
And the error of each cell is defined as follows:
 $$\begin{equation}
{\Delta _j} = \frac{{\sum {{\Delta _{{\rm{Ne}}{{\rm{t}}_j}}}} }}{4}
\end{equation}$$
The error vector of all calibration cells is shown as:
 $$\begin{equation}
\Delta = [{{\Delta _1},{\Delta _2},{\Delta _3},{\Delta _j}, \ldots {\Delta _m}} ]{^T}\quad \left( {j = 1,2,3, \ldots m} \right),
\end{equation}$$
where m is the total number of the calibration cells. The cell that has the smallest error will be chosen as the impact cell according to the following formula:
 $$\begin{equation}
\overline {{\rm{Net}}} \left( q \right) = Min\left[\Delta \right],
\end{equation}$$
where q is the number of the cell whose error is minimum. The second step is to search for the impact location in the determined cell. Through the reciprocal of the error of the four calibration points in the cell and the coordinates of the four calibration points, the impact location is estimated by a centre-of-gravity method:
 $$\begin{equation}
{x_c} = \frac{{\sum\nolimits_{i = 1}^4 {\frac{1}{{{\delta _{{n_{qi}}}}}}{x_i}} }}{{\sum\nolimits_{i = 1}^4 {\frac{1}{{{\delta _{{n_{qi}}}}}}} }},\quad \;{y_c} = \frac{{\sum\nolimits_{i = 1}^4 {\frac{1}{{{\delta _{{n_{qi}}}}}}{y_i}} }}{{\sum\nolimits_{i = 1}^4 {\frac{1}{{{\delta _{{n_{qi}}}}}}} }},
\end{equation}$$
where xi and yi are the transverse and longitudinal coordinates of the four calibration points in the selected cell, respectively, and where xc and yc are the estimated locations of the current impact event.
2.2 Impact force reconstruction method
In low-velocity impact events, the relationship between the impact force and structural response can be approximated as linear when the structure deformation can be considered to be linearly elastic during the impact process and when the deformation of the structure is small enough to neglect geometric non-linearity, and the impact force is constructed by the transfer function and structure response(Reference Park, Ha and Chang14).
 $$\begin{equation}
{F_{(x,y)}} = HS,
\end{equation}$$
where H is the transfer function between the response signal and the impact force and S is the output response signal of the sensor at the time domain.
In general, the impact location is arbitrary in the monitoring area, so it is necessary to obtain the transfer function at any point in the monitoring area. The transfer function at any point can be acquired by linear interpolation(Reference Park, Ha and Chang14) of the transfer functions of the four neighbouring calibration points as shown in Fig. 3. The transfer function of arbitrary location is defined in the following formula:
 $$\begin{equation}
{\bar H_{({x_c},{y_c})}} = \sum\limits_{i = 1}^4 {{\lambda _i}} {H_i},
\end{equation}$$
where 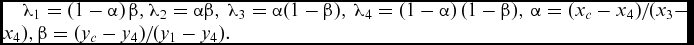 ${\lambda _1} = ( {1 - \alpha } )\,\beta ,{\lambda _2} = \alpha \beta ,\,{\lambda _3} = \alpha ( {1 - \beta } ),\,{\lambda _4} = ( {1 - \alpha } )\,( {1 - \beta } ),\, \alpha = {{( {{x_c} - {x_4}} )}
/} {{( {x_3} -}}$ ${{ {x_4} )}},\beta = {{( {{y_c} - {y_4}} )}
/ {( {{y_1} - {y_4}} )}}. $
The transfer function at an arbitrary point.
Multiple sensor signals can get more information than a single sensor in the structure, so it is much better to reconstruct the impact force with multiple sensors. Assuming four sensors are used to reconstruct the impact force and the four signals of sensors are S 1, S 2, S 3, S 4, respectively; the impact forces reconstructed from each sensor are F 1, F 2, F 3, F 4, respectively; and the mean of calculated forces from four sensors is chosen as the impact force time history, which is shown in the following equation:
 $$\begin{equation}
{F_{(x,y)}} = ({\bar H_1}{S_1} + {\bar H_2}{S_2} + {\bar H_3}{S_3} + {\bar H_4}{S_4})/4
\end{equation}$$
The impact force time history can be approximated as a half sine wave, and there is just a slight difference between the loading and unloading stages(Reference Chang38). The maximum amplitude of the impact force is an important factor associated with whether the structure is damaged or not. Therefore the half pulse of the impact force is chosen as the recognition of the impact force time history. A complete history of the impact force can be obtained by the symmetry operation of the half pulse, thereby simplifying the transfer function for the reconstruction of the impact force. As shown in Fig. 4, a typical impact force time history curve is plotted with the blue solid line, which is simplified to a symmetrical pulse load time history with the blue dotted line, and the red line is the reconstructed force time history.
A typical impact force time history diagram.
In this paper, the impact source is a point source on the structure. Two impactors with different hardnesses are investigated: the steel impactor and rubber impactor. The radius of the rubber tip is bigger than that of the steel tip and the tip of the rubber impactor is softer than that of the steel impactor, so the contact radius of rubber tip is bigger than that of the steel tip in impact events, and the geometry details of the steel and rubber tips are shown in Fig. 5(b). As shown in the Fig. 5(a), the signal spectrums are different for the two different impactors. The impact force time history and the corresponding response signal are used to build the transfer function by two different tips, respectively. The transfer functions for two different tips can be identified through the spectral differences of sensor signals by the correlation co-efficient shown in Equation (2.17).
 $$\begin{equation}
{\rho _{xy}} = \frac{{\sum\nolimits_{i = 1}^n {\left[{\left( {x(i) - {\mu _x}} \right)\left( {y(i) - {\mu _y}} \right)} \right]} }}{{{{\left[{\sum\nolimits_{i = 1}^n {{{\left( {x(i) - {\mu _x}} \right)}^2}\centerdot \sum\nolimits_{i = 1}^n {{{\left( {y(i) - {\mu _y}} \right)}^2}} } } \right]}^{^1{\!/\!}_{2}}}}}
\end{equation}$$
Signal spectrums caused by different tips.
Suppose x(i) and y(i) are two different signal frequency spectrums, μx and μy are the mathematical expectations of x(i) and y(i) respectively, and ρxy is the correlation coefficient of x(i) and y(i). The signal frequency spectrum of each calibration point is acquired by calibration work for two impactor tips. The correlation coefficients of the current impact signal for the steel tip and the rubber tip can be calculated, respectively. As a result, a proper transfer function can be chosen by the maximum correlation coefficient to get a better estimation of the impact force time history.
Impact location is updated around the initial impact position in order to find the minimal error of reconstructed forces from multiple sensors to identify the impact location and force time history. The location-update process is based on the idea proposed by Park et al in 2009(Reference Park, Ha and Chang14).
Multiple sensors are used to reconstruct force history for reducing the error caused by the single sensor. Assuming only four sensors are included to reconstruct the impact force, the impact force is calculated as F 1, F 2, F 3, F 4 for each sensor, respectively. The solution for minimising the objective function Δlf as shown in Equation (2.18) can be sought by various methods. More details of the update procedure can be seen in the literature(Reference Park, Ha and Chang14). In this study, the objective function is solved by the method of co-ordinate rotation in a range of the initial position to find the minimum.
 $$\begin{equation}
{\Delta _{lf}} = {({F_1} - {F_2})^2} + {({F_1} - {F_3})^2} + {({F_1} - {F_4})^2} + {({F_2} - {F_3})^2} + {({F_2} - {F_4})^2} + {({F_3} - {F_4})^2}
\end{equation}$$
Therefore, the impact location and force time history are identified by this objective function.
3.0 EXPERIMENT
3.1 Experiment setup
The impact identification experiment is implemented on a flat glass fibre-epoxy matrix woven composite plate. Figure 6 shows the experiment setup. The plate (123cm × 103cm × 0.3cm) is fixed on a table by eight clamps around the edges of the plate. Figure 6 gives the position of the four sensors (diameter: 6.5mm; thickness: 0.25mm) which are mounted on the corner of the monitoring zone in the plate, and the distance between two sensors is 20cm. The impact response from sensors and the impact force of the hand-held instrumented hammer are acquired by a multi-channel acquisition system with the sample rate of 40kHz. The in-plane strain response and the impact force are proportional to the output voltage of the piezoelectric sensor and instrumented hammer, respectively. The output of the piezoelectric sensor of the hammer is the charge signal, and the charge unit can be converted to Newton units by the sensitivity coefficient (4.46pc/N). In some cases it might be useful to estimate the impact force even if no significant damage is anticipated (e.g. to track potential damage due to repeated impacts). It is noted that all the impact forces are perpendicular to the plate surface and there is no induced impact damage on the plate after impact.
The impact monitoring zone and sensor distribution.
3.2 The signal analysis
The impulse load of the impact force will generate the transient signal of the piezoelectric sensor, which has broad frequency bandwidth and is vulnerable to the influence of the environment. Hence, extracting the useful components of the signal is the key to identify the impact source. The Fourier transform shows the distribution of various frequency components of a signal. Then, the main frequency components of the signal can be extracted to the identification algorithm and the sample frequency will be checked and confirmed. The fast Fourier transform (FFT) is used to analyse a signal. For example, the impact with the steel tip of the hammer occurs at the centre of the sample plate and Fig. 7 shows the response signal and signal frequency spectrum of sensor 1. The sample frequency is 40kHz, and the main frequency components are in the range of low frequency (<5kHz). So the sample frequency of the data acquisition system is enough to get full information of the signal according to the sampling theorem.
The impact signal of sensor 1 for (a) original signal; (b) the signal frequency spectrum.
The Discrete Wavelet Transform (DWT) usually adopts Mallat's tower algorithm for discrete binary wavelet transform which decomposes a signal into its approximations and details. The Db5 wavelet function is used in the DWT decomposition to extract useful features of a signal. The Db5 is the fifth-order Daubechies wavelet, and the high regularity of the Daubechies wavelet is useful in estimating the local properties of a signal. As shown in Fig. 7(b), most main components of the frequency spectrum are below about 1kHz, and the useful main information in the signal should be extracted subtly. The useful main components of the signal of sensor 1 are extracted by DWT using the Db5 wavelet function at level 5, so the frequency of main components of the signal is below 1.25kHz. The extracted signal of sensor 1 is shown in Fig. 8(a), and the frequency spectrum of the original and extracted signals is compared by FFT in Fig. 8(b). Obviously, the main components of the frequency spectrum of the extracted signal are below 1kHz, and the useful main information of the signal is extracted for the impact identification.
The extracted signal of sensor 1 for (a) time domain signal and (b) frequency domain signal.
3.3 The calibration work and impact test
An experiment is conducted to verify the effectiveness of the impact identification algorithm. The calibration work for the calibration points should be done before the impact test, and the basis vector of sensor signal and the transfer function for each calibration point are acquired simultaneously in the calibration work. The transfer function at an arbitrary location can be obtained by the linear interpolation of the transfer functions of calibration points. The calibration work is performed using the impact test in this paper. The calibration points on the grid nodes in the monitoring area are impacted to complete the calibration work by a hammer with a steel tip and rubber tip, respectively. As shown in Fig. 2, only the half zone of the monitoring area is calibrated and tested because of the symmetry of the monitoring area. The accuracy of the impact identification will become greater when the calibration points are closer, but the time cost will increase and the efficiency will reduce as the density of the calibration points increases, and the interval of calibration points is 25mm in this paper.
4.0 RESULTS AND DISCUSSION
In order to validate the proposed impact identification algorithm, the impact test is performed in the monitoring area of the glass fibre-epoxy matrix composite plate by the hammer with steel and rubber tips, respectively. The impact test is performed at arbitrary locations in the monitoring area, including the calibration points and the non-calibration points.
4.1 Impact location estimation
Arbitrary points in the test specimen are impacted by a hammer with two different tips. From the impact experiment, the sensor signals are acquired and the impact locations are estimated by the proposed impact identification algorithm. The initial position of the impact point is estimated using the basis vector method described in the previous chapter. The basis vector in this paper only uses the signal power of sensors to estimate the impact location. The different hammer tips have different hardnesses with different radiuses, and the contact radius of the rubber tip is bigger than that of the steel tip in impact events. The basis-vector-based localisation method is based on the signal power. The difference between two basis vectors at different positions is the key for this method, so obviously the two different kinds of tips don't affect the differences of basis vectors.
The applicability of the basis vector method is checked by impact experiment with the steel tip and the rubber tip. Firstly, the basis vector of each calibration point of the monitoring zone shown in Fig. 2 is calibrated through the experiment by the hammer with the rubber tip. Secondly, the impact test is carried out at arbitrary points in the monitoring zone with two different tips.
The error of the location estimation is defined as the ratio of the distance from the estimated position to the real position and the sensor spacing, and the error is shown as follows:
 $$\begin{equation}
\begin{array}{l} \Delta x = \displaystyle\frac{{\left( {{x_{{\rm{cal}}}} - {x_{{\rm{real}}}}} \right)}}{{\Delta {x_{{\rm{sensors}}}}}} \times 100\% \\[8pt] \Delta y = \displaystyle\frac{{\left( {{y_{{\rm{cal}}}} - {y_{{\rm{real}}}}} \right)}}{{\Delta {y_{{\rm{sensors}}}}}} \times 100\% \\[8pt] {\rm{Location}}\;{\rm{error}} = \sqrt {\Delta {x^2} + \Delta {y^2}} \end{array}
\end{equation}$$
where x cal and y cal are the estimated impact location, x real and y real are the real impact locations, and Δx sensors and Δy sensors are the sensor spacing, which is 20cm in this study.
The initial position of the impact location is estimated by the basis vector method without the position update from multiple sensors, and Fig. 9 demonstrates the errors of the initial impact position detection by two different tips at arbitrary locations, which includes 35 different calibration points and 19 arbitrary non-calibration points of the zone in the monitoring area. The points of the Figs 9(a) or 9(b) represent the errors of different impact locations, and the average errors of the position estimation by the rubber tip and the steel tip are 2.3% and 4.4%, respectively. As a result, the basis vector method is fit for the two different tips.
The errors of the initial position estimation: (a) rubber, (b) steel.
Based on the initial position estimation by the basis vector method, an update of the position is conducted by Equation (2.18) around the estimated initial position. The final estimated position of the impact location is shown in Fig. 10 for the rubber tip and the steel tip. The average errors of the position estimation by the rubber tip and the steel tip are 2.6% and 2.8%, respectively, after the update. Therefore, the impact identification algorithm is feasible for identifying the impact location of impact events.
The errors of the final position estimation: (a) rubber, (b) steel.
4.2 Impact Force Reconstruction
The impact force time history is reconstructed in the position of the calibration and non-calibration points. The error of the impact force reconstruction is defined as follows:
 $$\begin{equation}
{\rm{Force}}\;{\rm{error}} = \frac{{\left| {{\rm{Max}}\left( {{F_{{\rm{cal}}}}} \right) - {\rm{Max}}\left( {{F_{{\rm{real}}}}} \right)} \right|}}{{{\rm{Max}}\left( {{F_{{\rm{real}}}}} \right)}} \times 100\%
\end{equation}$$
where F cal is the calculated impact force time history and F real is the real impact force time history.
Among the monitoring zone in Fig. 11, ten different points are detected by two different tips, respectively. The force reconstruction is calculated by the corresponding transfer function and the sensor signal. The transfer function is obtained by the linear interpolation of the transfer functions at calibration points, and the transfer function for the rubber tip or the steel tip is chosen by the correlation coefficient. Figure 12 displays two examples of the impact load identification; the impact forces are tested by two different tips, and the reconstructed force time history presents a good fit to the real force time history. Obviously, the reconstruction results of point 4 in Fig. 12(a) are better than the results of point 5 in Fig. 12(b), because the transfer function of the non-calibration point 5 is obtained by the interpolation, which may include error.
The impact test points and sensor distribution.
The impact force reconstruction by two different tips for (a) point 4 and (b) point 5.
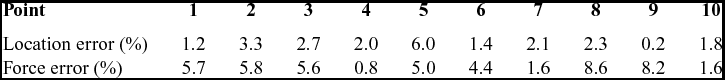
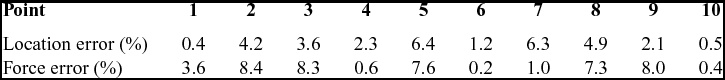
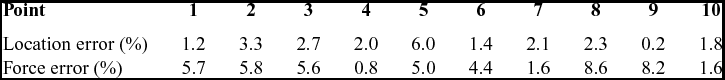
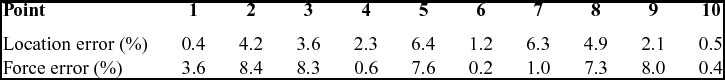
The identification results of the ten impact test points are shown in Tables 1 and 2 for the rubber tip and the steel tip, respectively. The error of the location estimation and the error of the reconstructed force are low enough to meet the need of the engineering. According to the above results, it can be seen that impact events can be estimated well for the location and the impact force time history using basis vectors and transfer functions.
The errors of different points by the rubber tip
The errors of different points by the steel tip
4.3 Large sensor layout
In order to investigate the feasibility of the impact identification algorithm, a different sensor layout is used to identify the impact events. As shown in Fig. 13, the impact test is performed on a quarter of the composite plate by rubber impactor; four sensors are mounted near the corner of the plate, 12cm from each side of the plate. The transverse spacing Δx sensors and the longitudinal spacing Δy sensors are 99cm and 79cm, respectively. Figure 13 shows the sensor location, calibration locations, and impact locations on the plate.
Sensor, impact and calibration locations with 50mm spacing.
First of all, the impact location is estimated by the proposed localisation method in Section 2.1. As shown in Fig. 14(a), the average error is 10.8%, but the errors of the position estimation are large at some impact points. Obviously, the impact localisation errors in the large sensor layout are larger than the errors in the small sensor layout. There are some issues may affect the accuracy of the localisation. (Reference Van Tooren, Kasapoglou and Bersee1) The sensors of the large sensor layout are close to the boundary of the plate and the sensor signal is affected by the complex boundary conditions, such as the reflection, modal conversion, super-position and so on. (Reference Cheng2) The interval of calibration points in the large sensor layout is larger than that in the small sensor layout, and the accuracy of the impact identification will become greater when the calibration points are closer. Therefore, the localisation method is improved to get precise results, which are shown in Fig. 14(b), and the average error is 6.7%.
The errors of the position estimation: (a) original method, (b) improved method.
To improve the localisation method, the arrival time is used to organise a basis vector to get more information about the impact source. Sensor 1 is chosen as the reference sensor, and the time difference is defined according to the reference sensor. The basis vector of the arrival time is described as:
 $$\begin{equation}
{\xi _T}\left( {x,y} \right) = \left[{{t_{11}},{t_{21}},{t_{31}},{t_{41}}} \right]
\end{equation}$$
The error between any calibration point and the current impact location defined in Equation (2.6) and Equation (2.7) is improved as:
 $$\begin{equation}
\left\{ \begin{array}{l} \delta _P^i = \frac{{\sum {{{\left( {\xi _P^*\left( {{x_*},{y_*}} \right) - \xi _P^i\left( {{x_i},{y_i}} \right)} \right)}^2}} }}{{\sum {{{\left( {\xi _P^i\left( {{x_i},{y_i}} \right)} \right)}^2}} }}\quad \left( {i = 1,2,3, \ldots n} \right)\\[8pt] \delta _T^i = \frac{{\sum {{{\left( {\xi _T^*\left( {{x_*},{y_*}} \right) - \xi _T^i\left( {{x_i},{y_i}} \right)} \right)}^2}} }}{{\sum {{{\left( {\xi _T^i\left( {{x_i},{y_i}} \right)} \right)}^2}} }}\quad \left( {i = 1,2,3, \ldots n} \right)\\[8pt] {\delta _i} = \sqrt {{{\left( {\delta _P^i} \right)}^2} + {{\left( {\delta _T^i} \right)}^2}} \end{array} \right.
\end{equation}$$
where ξ*p and ξ*T are power basis vector and time basis vector, respectively, at the current impact event, and ξip and ξiT are power basis vector and time basis vector, respectively, at the ith calibration point.
For the impact force reconstruction, the results are shown in Fig. 15. The sensor whose transfer functions are precise is chosen to reconstruct the impact force in this test. As shown in Fig. 15, the errors of force reconstruction are large at some points. The sensor spacing is too large, so the sensor signal is weak, which will make the error of force reconstruction larger. Therefore, it is not recommended to use large sensor spacing, which should be chosen according to the real structure and the required accuracy.
The force errors of different points.
5.0 CONCLUSIONS
This paper presents an impact identification algorithm to identify the impact location and impact force time history by the basis vector method and simplified transfer functions. Based on the signal characteristic parameters, a basis vector method is proposed to locate the impact event using a small number of sensors (only four sensors used in this study). Meanwhile, the dimension of the transfer function is reduced using the first half pulse of the force signal to simplify the impact force history, while the maximum load information and the primary information of the impact force time history are retained. In order to identify the impact force precisely, the transfer functions for rubber impactors and steel impactors are selected automatically and correctly by the correlation coefficient because the two different impactors have different contact radiuses. Two impactors with different tips are used in the experiment to identify the feasibility of this algorithm on the flat glass fibre-epoxy matrix composite plate.
The average error in the impact location estimation by two different impactors is less than 5% according to the sensor spacing, and the impact force reconstruction is well in the small sensor layout. For the large sensor layout, the localisation error is about 6.7% according to the sensor spacing, and the error of the force reconstruction is larger than that of the small sensor layout. It is not recommended to use large sensor spacing, which should be chosen according to the real structure and the required accuracy. For the larger structure, the calibration points may increase and thus cost time, which is the limitation of this method based on calibrations. If the distributed sensors are located in the symmetrical structure location, the calibration points can be reduced by the advantage of the symmetry of the structure. The proposed impact source identification algorithm can accurately identify impact events on the composite plate in real time.
ACKNOWLEDGEMENTS
This work was supported by the National Natural Science Foundation of China (51475067, 11172053 and 91016024) and the New Century Excellent Talents in University (NCET-11-0055).