1. Introduction
The balancing methods of a manipulator have been developed in the last few decades. Advantages brought by the balancing of a manipulator such as decreasing the load of actuators and improving control performance have been proved [Reference Baradat, Arakelian, Briot and Guegan1–Reference Martini, Troncossi and Rivola3]. The methodology is expansively applied to numerous fields. For example, gravity balancer is used on many tools for surgery [Reference Woo, Seo and Yi4] or industry [Reference Hull, Turner and Asbeck5] to carry the weight of the hand tools and to improve stability during processing, thereby reducing worker injuries and improving productivity. For some automatic robotic arm [Reference Simionescu and Ciupitu6–Reference Arezoo, Arezoo and Fard8], springs are used to share the heavy weight, which reduce the load on the driving system. In the biomedical field, ref. [Reference Najafi and Sepehri9] proposed the design of a medical robot arm for ultrasound imaging, which used tension spring to achieve static balance; ref. [Reference Aldanmaz, Ayit, Kiper and Dede10] developed a gravity balanced 2R1T (2 rotations and 1 translation) mechanism and used it on surgery applications. Other applications such as upper arm exoskeletons [Reference Lin, Shieh and Chen11, Reference Tschiersky, Hekman, Herder and Brouwer12] and lower limb rehabilitation devices [Reference Arakelian and Ghazaryan13, Reference Kuo, Nguyen, Robertson, Chou and Herder14], with balancing of limbs’ weight, users can perform overhead work or rehabilitation easily.
Several balancing methods have been developed in history. For a serial planar manipulator with only revolute joints, the method to balance gravity with springs has been proposed by refs. [Reference Lin, Shieh and Chen15–Reference Juang and Chen18], of which the springs are directly attached to the manipulator. Ref. [Reference Juang, Jhuang and Chen19] further discussed the efficiency of using spring on balancing and has proposed a method to use spring efficiently. Other balancing methods can fully/partially balance gravity. The methods include adding modules formed by springs and auxiliary links [Reference Rahman, Ramanathan, Seliktar and Harwin20, Reference Lin, Shieh and Chen21] or having gravity compensators [Reference Arakelian and Zhang22–Reference Nguyen, Lin and Kuo24] and counterweight [Reference Kang, Oh, Kim and Yi25] on the manipulators. Besides serial planar manipulator, several studies developed gravity balance of spatial parallel mechanisms. Ref. [Reference Wang and Gosselin26] discussed two passive balance approaches with counterweights and with springs; ref. [Reference Nguyen, Lin and Kuo27] developed a gravity compensator composed of gears and springs; ref. [Reference Yang, Huang, Jiang, Peter and Han28] proposed a dynamic gravity compensation controller for a parallel manipulator. With these balancing methods, the gravity of devices can be fully or partially compensated.
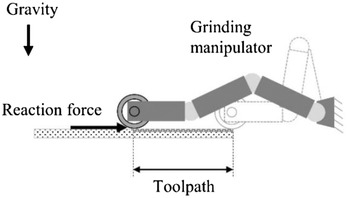
While researches in the past focused mainly on the balancing of gravity, manipulators do not just bear forces in the direction of gravity during actual operation. For example, in an industry manipulator for drilling [Reference Alici29, Reference Marino, Cirillo, Natale, Chiacchio and Pirozzi30] or grinding [Reference Rafieian, Liu and Hazel31], the actuators bear reaction forces between the end effector and the workpieces in various directions (as shown in Fig. 1.) Moreover, for a long continuous toolpath, the reaction forces are applied on the manipulator for even longer, which greatly increases the load on the actuators. Such situation is not considered in the past researches, and the balance methods cannot be applied to non-gravity directional forces, thus limiting the application of this technique. This study is a pioneering attempt in developing a method that uses springs to balance constant forces in arbitrary directions for a planar serial manipulator. Similar to the balancing of gravity, if the forces on manipulators can be fully balanced or partially compensated, it will help to reduce the actuator load.
A grinding manipulator with reaction force between the end effector and the workpiece.

Our approach differs from the past works, in addition to the gravity, balancing of forces in arbitrary directions are included. Also, additional balancing device such as auxiliary links or counterweight are not required in this method, the tension springs are directly attached on the manipulator and used to balance the forces. This method can be widely used in many fields, such as the design of industry manipulators or the design of wearable devices for human upper/lower limbs.
The structure of this paper is as follows: Section 2 models a n-links planar manipulator with springs and only revolute joints. Since the attached points of a spring that is on the links are expressed in polar coordinate system, the attachment parameters of a spring include attachment distances and attachment angles. Based on the modeling of the spring-manipulator system, the formulation of the potential energy of a constant force and the spring’s energy in the quadratic form is derived. Accordingly, the balancing conditions are obtained. The balancing conditions show that the springs are supposed to be attached at specific angles to ensure they contribute to the balancing. Hence, in Section 3, the ideal spring attachment angles are proposed. Besides the attachment angles, to ensure the energy of the planar forces can be fully offset, the springs are required to be installed in specific locations. As for Section 4, it presents the arrangement of springs that serve to balance the constant forces applied on a 3-degrees-of-freedom (3-DoF) manipulator. Then in Section 5, a spring-balanced grinding manipulator is shown as an example. Finally, Section 6 serves as a conclusion of the study.
2. Balancing Constant Forces in Arbitrary Directions with Springs
2.1. Quadratic form of the potential energy of constant forces
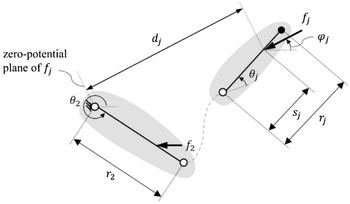
Figure 2 shows a planar serial manipulator with revolute joints only. A constant force in arbitrary directions is applied on the link. As shown in Fig. 2,
 $r_{j}$
is the length of link
 $j$
;
 $\theta _{j}$
is the rotation angle of link
 $j$
;
 $\,f_{j}$
is the constant force in arbitrary direction
 $\varphi _{j}$
that is applied on link
 $j$
;
 $s_{j}$
is the distance between the joint and the location that
 $f_{j}$
is applied on;
 $d_{j}$
is the distance between the location that
 $f_{j}$
is applied on and the zero-potential plane of
 $f_{j}$
(here set as the plane perpendicular to
 $f_{j}$
and passing through the joint between the ground link and the 2nd link.)
A revolute joints only planar serial manipulator with a constant force in an arbitrary direction.

The potential energy of the planar forces is expressed as
 \begin{equation} U_{f\left(j\right)}=f_{j}d_{j} \end{equation}
The distance between the location of
 $f_{j}$
and the zero-potential plane is expressed as
 \begin{equation} d_{j}=s_{j}\cos\!\left(\varphi _{j}-\sum _{t=2}^{j}{\unicode[Arial]{x03B8}} _{\mathrm{t}}\right)+\sum _{v=2}^{j-1}r_{v}\cos\!\left(\varphi _{j}-\sum _{t=2}^{v}{\unicode[Arial]{x03B8}} _{\mathrm{t}}\right) \end{equation}
Substituting Eq. (2) into Eq. (1), the energy of the planar forces can be rewritten as
 \begin{equation} U_{f\left(j\right)}=f_{j}s_{j}\cos\!\left(\varphi _{j}-\sum _{t=2}^{j}\theta _{t}\right)+f_{j}\sum _{v=2}^{j-1}r_{v}\cos\!\left(\varphi _{j}-\sum _{t=2}^{v}\theta _{t}\right) \end{equation}
Equation (3) can be expressed in quadratic form as
 \begin{equation} U_{f\left(j\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] \vdots \\[5pt] r_{j}\\[5pt] \vdots \\[5pt] r_{n} \end{array}\right]^{T}\mathbf{W}_{f\left(j\right)}\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] \vdots \\[5pt] r_{j}\\[5pt] \vdots \\[5pt] r_{n} \end{array}\right] \end{equation}
in which matrix
 $\mathbf{W}_{f(j)}$
is a
 $j\times j$
square matrix with non-zero components locate at the first row as follows:
 \begin{equation} \mathbf{W}_{f\left(j\right)}=\left[\begin{array}{c@{\quad}c@{\quad}c@{\quad}c@{\quad}c} 0 & W_{1,2}^{f\left(j\right)} & W_{1,3}^{f\left(j\right)} & \ldots & W_{1,j}^{f\left(j\right)}\\[5pt] 0 & 0 & 0 & 0 & 0\\[5pt] 0 & 0 & 0 & \vdots & \vdots \\[5pt] \vdots & \vdots & \vdots & 0 & 0\\[5pt] 0 & 0 & 0 & 0 & 0 \end{array}\right] \end{equation}
The non-zero components in the matrix are as follows:
 \begin{equation} W_{1,j}^{f\left(j\right)}=\frac{f_{j}}{r_{1}}\frac{s_{j}}{r_{j}}\cos\!\left(\varphi _{j}-\sum _{t=2}^{j}\theta _{t}\right) \end{equation}
 \begin{equation} W_{1,v}^{f\left(j\right)}=\frac{f_{j}}{r_{1}}\cos\!\left(\varphi _{j}-\sum _{t=2}^{v}\theta _{t}\right)\;\;\;\;\;\mathrm{for}\;j\gt v\geq 2 \end{equation}
The matrix components
 $W_{1,j}^{f(j)}$
are in unit of stiffness (
 $N/m$
), which can be regarded as a “pseudo-stiffness” between ground link (link 1) and link
 $j$
. The pseudo-stiffness represents the change of energy with the relative posture between two links. Such representation can show the relationship between energy and manipulator’s posture clearly.
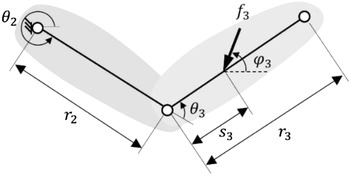
Take a 2-DoFs planar manipulator with constant force
 $f_{3}$
shown in Fig. 3 as an illustrative example.
A 2-DoF planar manipulator with a constant force.

According to Eq. (5), the potential energy can be expressed in quadratic form as follows
 \begin{equation} U_{f\left(3\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3} \end{array}\right]^{T}\left[\begin{array}{c@{\quad}c@{\quad}c} 0 & W_{1,2}^{f\left(3\right)} & W_{1,3}^{f\left(3\right)}\\[5pt] 0 & 0 & 0\\[5pt] 0 & 0 & 0 \end{array}\right]\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3} \end{array}\right] \end{equation}
Also, according to Eqs. (6a), (6b), the non-zero components
 $W_{1,2}^{f(3)}$
and
 $W_{1,3}^{f(3)}$
can be respectively expressed as
 \begin{equation} W_{1,2}^{f\left(3\right)}=\frac{f_{3}}{r_{1}}\cos\!\left(\varphi _{3}-\theta _{2}\right) \end{equation}
 \begin{equation} W_{1,3}^{f\left(3\right)}=\frac{f_{3}}{r_{1}}\frac{s_{3}}{r_{3}}\cos\!\left(\varphi _{3}-\theta _{2}-\theta _{3}\right) \end{equation}
2.2. Quadratic form of the elastic energy
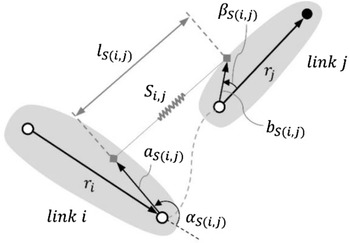
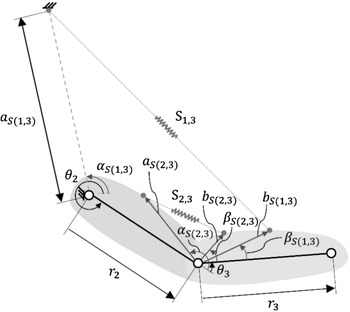
As shown in Fig. 4, a zero-free-length (ZFL) extension spring
 $S_{i,j}$
with spring stiffness
 $k_{S(i,j)}$
is attached between link
 $i$
and link
 $j$
. The ZFL spring means that the length of the spring is its elongation while maintaining zero length under unstretched conditions. The lengths of link
 $i$
and
 $j$
are
 $r_{i}$
and
 $r_{j}$
;
 $l_{S(i,j)}$
is the elongation of spring
 $S_{i,j}$
;
 $a_{S(i,j)}$
is the attachment distance of
 $S_{i,j}$
on the proximally attached link
 $i$
;
 $b_{S(i,j)}$
is the attachment distance of
 $S_{i,j}$
on the distally attached link
 $j$
;
 $\alpha _{S(i,j)}\;$
is the attachment angle of
 $S_{i,j}$
on the proximally attached link
 $i$
; and
 $\beta _{S(i,j)}\;$
is the attachment angle of
 $S_{i,j}$
on the distally attached link
 $j$
. In this study, only extension springs are considered. Therefore,
 $k_{S(i,j)}$
is a positive value; likewise,
 $a_{S(i,j)}$
and
 $b_{S(i,j)}$
, which refer to distances, must also be positive.
A ZFL spring attached between links
 ${i}$
and
 ${j}$
.

The elastic potential energy of the zero-free length spring
 $S_{i,j}$
, which is attached between links
 $i$
and
 $j$
, can be expressed as
 \begin{equation} U_{S\left(i,j\right)}=\frac{1}{2}k_{S\left(i,j\right)}l_{S\left(i,j\right)}^{2} \end{equation}
where the elongation of
 $S_{i,j}$
is expressed as
 \begin{equation} l_{S\left(i,j\right)}=\vec {b}_{S\left(i,j\right)}-\vec {a}_{S\left(i,j\right)}+\sum _{t=i+1}^{j-1}\vec {r}_{t} \end{equation}
Substituting Eq. (10) into Eq. (9),
 $U_{S(i,j)}$
can be presented as
 \begin{equation*} U_{S\left(i,j\right)}=\frac{1}{2}k_{S\left(i,j\right)}\left(a_{S\left(i,j\right)}^{2}+b_{S\left(i,j\right)}^{2}+\sum _{t=i+1}^{j-1}r_{t}^{2}\right)+r_{i}r_{j}K_{i,j}^{S\left(i,j\right)}+\sum _{v=i+1}^{j-1}r_{i}r_{v}K_{i,v}^{S\left(i,j\right)} \end{equation*}
 \begin{equation} +\sum _{u=i+1}^{j-1}r_{u}r_{j}K_{u,j}^{S\left(i,j\right)}+\sum _{u=i+1}^{j-2}\sum _{v=u+1}^{j-1}r_{u}r_{v}K_{u,v}^{S\left(i,j\right)} \end{equation}
where
 \begin{equation} K_{i,j}^{S\left(i,j\right)}=k_{S\left(i,j\right)}\frac{a_{S\left(i,j\right)}}{r_{i}}\frac{b_{S\left(i,j\right)}}{r_{j}}\cos\!\left(\pi +\alpha _{S\left(i,j\right)}-\beta _{S\left(i,j\right)}-\sum _{t=i+1}^{j}\theta _{t}\right) \end{equation}
 \begin{equation} K_{i,v}^{S\left(i,j\right)}=k_{S\left(i,j\right)}\frac{a_{S\left(i,j\right)}}{r_{i}}\cos\!\left(\pi +\alpha _{S\left(i,j\right)}-\sum _{t=i+1}^{v}\theta _{t}\right)\;\;\;\text{for}\,v\lt j \end{equation}
 \begin{equation} K_{u,j}^{S\left(i,j\right)}=k_{S\left(i,j\right)}\frac{b_{S\left(i,j\right)}}{r_{j}}\cos\!\left(\!-\!\beta _{S\left(i,j\right)}-\sum _{t=u+1}^{j}\theta _{t}\right)\;\;\;\text{for}\,u\gt i \end{equation}
 \begin{equation} K_{u,v}^{S\left(i,j\right)}=k_{S\left(i,j\right)}\cos\!\left(\!-\!\sum _{t=u+1}^{v}\theta _{t}\right)\;\;\;\mathrm{for}\;u\gt i;\;v\lt j \end{equation}
Equation (11) can also be represented in quadratic form as
 \begin{equation} U_{S\left(i,j\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] \vdots \\[5pt] r_{i}\\[5pt] \vdots \\[5pt] r_{j}\\[5pt] \vdots \\[5pt] r_{n} \end{array}\right]^{T}\mathbf{K}_{S\left(i,j\right)}\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] \vdots \\[5pt] r_{i}\\[5pt] \vdots \\[5pt] r_{j}\\[5pt] \vdots \\[5pt] r_{n} \end{array}\right] \end{equation}
where the matrix
 $\mathbf{K}_{S(i,j)}$
is a square matrix with non-zero components locate at the area bounded by row
 $i$
, column
 $j$
, and the diagonal as follows,
 \begin{equation} \mathbf{K}_{S\left(i,j\right)}=\left[\begin{array}{c@{\quad}c@{\quad}c@{\quad}c@{\quad}c@{\quad}c@{\quad}c@{\quad}c} 0 & 0 & 0 & \;& \ldots & \;& 0 & 0\\[5pt] 0 & 0 & \ddots & \;& \ldots & \;& \;& 0\\[5pt] 0 & \vdots & * & K_{i,i+1}^{S\left(i,j\right)} & \ldots & K_{i,j}^{S\left(i,j\right)} & \;& \;\\[5pt] \;& \;& \;& * & K_{u,v}^{S\left(i,j\right)} & \vdots & \vdots & \vdots \\[5pt] \vdots & \vdots & \;& \;& * & K_{j-1,j}^{S\left(i,j\right)} & \;& \;\\[5pt] \;& \;& \;& \;& \;& * & \ddots & 0\\[5pt] \;& \;& \;& \;& \;& \;& 0 & 0\\[5pt] 0 & 0 & \;& \;& \ldots & \;& 0 & 0 \end{array}\right] \end{equation}
The matrix component
 $K_{u,v}^{S(i,j)}$
is a pseudo-stiffness between link
 $u$
and link
 $v$
, which represents the change of elastic energy with the relative posture between link
 $u$
and link
 $v$
. Note that, the components in the diagonal of the matrix
 $\mathbf{K}_{S(i,j)}\;$
(i.e.,
 $*$
in the diagonal of the matrix) are the constant terms in Eq. (11) (i.e., the terms:
 $\frac{1}{2}k_{S\left(i,j\right)}\left(a_{S\left(i,j\right)}^{2}+b_{S\left(i,j\right)}^{2}+\sum _{t=i+1}^{j-1}r_{t}^{2}\right)$
).
Here, take the 2-DoF planar manipulator in Fig. 3, which is attached by springs
 $\mathrm{S}_{1,3}\;$
and
 $\mathrm{S}_{2,3}$
as shown in Fig. 5, as an example.
A 2-DoFs planar articulated manipulator attached with two springs.

According to Eq. (13), the elastic energy of springs
 $\mathrm{S}_{1,3}\;$
and
 $\mathrm{S}_{2,3}$
in quadratic form are
 \begin{equation} U_{S\left(1,3\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3} \end{array}\right]^{T}\mathbf{K}_{S\left(1,3\right)}\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3} \end{array}\right] \end{equation}
 \begin{equation} U_{S\left(2,3\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3} \end{array}\right]^{T}\mathbf{K}_{S\left(2,3\right)}\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3} \end{array}\right] \end{equation}
According to Eq. (14), the matrix
 $\mathbf{K}_{S(1,3)}$
and
 $\mathbf{K}_{S(2,3)}$
are
 \begin{equation} \mathbf{K}_{S\left(1,3\right)}=\left[\begin{array}{c@{\quad}c@{\quad}c} * & K_{1,2}^{S\left(1,3\right)} & K_{1,3}^{S\left(1,3\right)}\\[5pt] \;& * & K_{2,3}^{S\left(1,3\right)}\\[5pt] \;& \;& * \end{array}\right] \end{equation}
 \begin{equation} \mathbf{K}_{S\left(2,3\right)}=\left[\begin{array}{c@{\quad}c@{\quad}c} * & 0 & 0\\[5pt] \;& * & K_{2,3}^{S\left(2,3\right)}\\[5pt] \;& \;& * \end{array}\right] \end{equation}
And from Eqs. (12a)–(12d), the components in
 $\mathbf{K}_{S(1,3)}$
and
 $\mathbf{K}_{S(2,3)}$
are
 \begin{equation} K_{1,2}^{S\left(1,3\right)}=k_{S\left(1,3\right)}\frac{a_{S\left(1,3\right)}}{r_{1}}\cos\!\left(\pi +\alpha _{S\left(1,3\right)}-\theta _{2}\right) \end{equation}
 \begin{equation} K_{1,3}^{S\left(1,3\right)}=k_{S\left(1,3\right)}\frac{a_{S\left(1,3\right)}}{r_{1}}\frac{b_{S\left(1,3\right)}}{r_{3}}\cos\!\left(\pi +\alpha _{S\left(1,3\right)}-\beta _{S\left(1,3\right)}-\theta _{2}-\theta _{3}\right) \end{equation}
 \begin{equation} K_{2,3}^{S\left(1,3\right)}=k_{S\left(1,3\right)}\frac{b_{S\left(1,3\right)}}{r_{3}}\cos\!\left(\!-\!\beta _{S\left(1,3\right)}-\theta _{3}\right) \end{equation}
 \begin{equation} K_{2,3}^{S\left(2,3\right)}=k_{S\left(2,3\right)}\frac{a_{S\left(2,3\right)}}{r_{2}}\frac{b_{S\left(2,3\right)}}{r_{3}}\cos\!\left(\pi +\alpha _{S\left(2,3\right)}-\beta _{S\left(2,3\right)}-\theta _{3}\right) \end{equation}
Here, the potential energy of the constant forces
 $U_{f(j)}$
(Eq. (5)) is balanced by the springs’ energy
 $U_{S(i,j)}$
(Eq. (13)). The balancing conditions are discussed in the following section.
2.3. Balancing conditions of constant forces in arbitrary directions
To balance a constant force in an arbitrary direction, the summation of the potential energy from forces and the elastic energy of springs should be equal to a constant.
 \begin{equation} \sum U_{f\left(j\right)}+\sum U_{S\left(i,j\right)}=\textit{constant} \end{equation}
The energy is represented in the quadratic form. To achieve balancing, the summation of the matrices
 $\mathbf{W}_{f(j)}$
and
 $\mathbf{K}_{S(i,j)}$
should be equal to a constant. According to Eqs. (6) and (14), since the components in the matrices’ diagonals are constant and the elements below the main diagonal are all zero, they can be neglected. Considering only the upper triangular matrix, the balancing equations can be expressed as
 \begin{equation} \sum W_{1,j}^{f\left(v\right)}+\sum K_{1,j}^{S\left(1,v\right)}=0\;\;\mathrm{for}\;v\geq j\gt 1 \end{equation}
and
 \begin{equation} \sum K_{i,j}^{S\left(u,v\right)}=0\text{for}\,i\geq u\gt 1;\;v\geq j \end{equation}
For example, if we take a look at Eqs. (19a), (19b) and substitute into them Eqs. (8a), (8b) and (17a)–(17d), then, to balance the forces applied on the 2-DoFs planar manipulator in Fig. 3 with the springs shown in Fig. 5, the balancing equations would then be
 \begin{align} \frac{f_{3}}{r_{1}}\cos\!\left(\varphi _{3}-\theta _{2}\right)&+k_{S\left(1,3\right)}\frac{a_{S\left(1,3\right)}}{r_{1}}\cos\!\left(\pi +\alpha _{S\left(1,3\right)}-\theta _{2}\right)=0 \\[5pt] & \frac{f_{3}}{r_{1}}\frac{s_{3}}{r_{3}}\cos\!\left(\varphi _{3}-\theta _{2}-\theta _{3}\right)\nonumber \end{align}
 \begin{align} &+k_{S\left(1,3\right)}\frac{a_{S\left(1,3\right)}}{r_{1}}\frac{b_{S\left(1,3\right)}}{r_{3}}\cos\!\left(\pi +\alpha _{S\left(1,3\right)}-\beta _{S\left(1,3\right)}-\theta _{2}-\theta _{3}\right)=0 \\[5pt] & k_{S\left(1,3\right)}\frac{b_{S\left(1,3\right)}}{r_{3}}\cos\!\left(\!-\!\beta _{S\left(1,3\right)}-\theta _{3}\right)\nonumber \end{align}
 \begin{equation} +k_{S\left(2,3\right)}\frac{a_{S\left(2,3\right)}}{r_{2}}\frac{b_{S\left(2,3\right)}}{r_{3}}\cos\!\left(\pi +\alpha _{S\left(2,3\right)}-\beta _{S\left(2,3\right)}-\theta _{3}\right)=0 \end{equation}
According to the example, since the parameters
 $k_{S(i,j)}$
,
 $a_{S(i,j)}$
,
 $b_{S(i,j)}$
,
 $r_{j}$
are positive value, the attachment angles
 $\alpha _{S(i,j)}$
and
 $\beta _{S(i,j)}$
are required to be attached at specific angles to satisfy the balancing Eqs. (20a)–(20c). The determination of spring attachment angles is discussed in the following section.
3. The Determination of Spring Attachment Angles for Balancing Constant Forces in Arbitrary Directions
3.1. The attachment angles of ground-connected springs
According to Eq. (6), the non-zero components of matrix
 $\mathbf{W}_{f(j)}$
are located in the first row only. To offset the non-zero components
 $W_{1,2}^{f(j)}, W_{1,3}^{f(j)}\ldots W_{1,n}^{f(j)}$
(i.e., to satisfy Eq. (19a)), the ground-connected springs
 $S_{1,j}$
, which can contribute non-zero components
 $K_{1,v}^{S(1,j)}$
for
 $j\geq v\geq 2$
, in the first row of
 $\mathbf{K}_{S(1,j)}$
, must be installed.
To ensure the springs are used to balance the planar forces rather than increasing the number of unbalanced components, the sign of components contributed by the ground-connected springs is regulated to be negative with their corresponding non-zero components in
 $\mathbf{W}_{f(j)}$
.
According to Eq. (6),
 $W_{1,v}^{f(j)}$
is a term to be balanced, and whether its sign will be positive/negative, it is determined by the angles in the cosine term. Similarly, according to Eqs. (12a)–(12d), the positive/negative signs of components provided by a spring are also determined by the angles in the cosine term. To use component
 $K_{1,v}^{S(1,j)}$
to balance the corresponding component
 $W_{1,v}^{f(j)}$
, there must be a
 $\pi$
difference between the angles in the cosine term of
 $K_{1,v}^{S(1,j)}$
and
 $W_{1,v}^{f(j)}$
. The constraints for attachment angles of a ground-connected spring are inferred as follows.
According to Eq. (14), the spring
 $S_{1,j}$
contributes the components,
 $K_{1,j}^{S(1,j)}$
and
 $K_{1,v}^{S(1,j)}$
, for
 $v\lt j$
in the first row of matrix
 $\mathbf{K}_{S(1,j)}$
. Then, according to Eqs. (12a), (12b), it can be seen that the angles in the two cosine terms
 $K_{1,j}^{S(1,j)}$
and
 $K_{1,v}^{S(1,j)}$
are
 $(\pi +\alpha _{S(1,j)}-\beta _{S(1,j)}-\sum _{t=2}^{j}\theta _{t})$
and
 $(\pi +\alpha _{S(1,j)}-\sum _{t=2}^{v}\theta _{t})$
, respectively.
According to Eq. (6), the angles in the cosine terms of the corresponding balanced components
 $W_{1,j}^{f(j)}$
and
 $W_{1,v}^{f(j)}$
for
 $v\lt j$
are
 $(\varphi _{j}-\sum _{t=2}^{j}\theta _{t})$
and
 $(\varphi _{j}-\sum _{t=2}^{v}\theta _{t})$
, respectively. Then, two constraints for attachment angles of ground-connected springs are found as below,
 \begin{equation} \left(\pi +\alpha _{S\left(1,j\right)}-\beta _{S\left(1,j\right)}-\sum _{t=2}^{j}\theta _{t}\right)-\left(\varphi _{j}-\sum _{t=2}^{j}\theta _{t}\right)=\pi \end{equation}
 \begin{equation} \left(\pi +\alpha _{S\left(1,j\right)}-\sum _{t=2}^{v}\theta _{t}\right)-\left(\varphi _{j}-\sum _{t=2}^{v}\theta _{t}\right)=\pi \end{equation}
From Eqs. (21a), (21b), the attachment angles of a ground-connected spring are required to be
 \begin{equation} \left(\alpha _{S\left(1,j\right)},\beta _{S\left(1,j\right)}\right)=\left(\varphi _{j},0\right) \end{equation}
Here, a special case is considered. If a ground-connected spring is attached between the ground link and the 2nd link (
 $S_{1,2}$
), it contributes only one component
 $K_{1,2}^{S(1,2)}$
; therefore, Eq. (21a) is the only constraint. The spring,
 $S_{1,2}$
, is required to be attached with angles that satisfy
 $\alpha _{S(1,2)}-\beta _{S(1,2)}=\varphi _{j}$
.
Though according to Eq. (14), a ground-connected spring with attachment angles
 $(\varphi _{j},0)$
can be used to balance the components
 $W_{1,2}, W_{1,3}\ldots W_{1,n}$
, there still exist non-zero components
 $K_{u,v}^{S(1,j)}$
for
 $u\gt 1$
below the first row of matrix which need to be balanced (i.e. to satisfy Eq. (19b)). Therefore, the installation of non-ground-connected springs is necessary. The determination of attachment angle for non-ground-connected springs is discussed in the following section.
3.2. The attachment angles of ground-connected springs
According to Eq. (14), the non-zero components below the first row of matrix remained by a ground-connected spring
 $S_{1,j}$
are
 $K_{u,j}^{S(1,j)}$
and
 $K_{u,v}^{S(1,j)}$
for
 $u\gt 1\;\mathrm{and}\;v\lt j$
. Also, by referring to Eqs. (12c), (12d), the components have angles in the cosine terms
 $(\!-\!\beta _{S(1,j)}-\sum _{t=u+1}^{j}\theta _{t})$
and
 $(\!-\!\sum _{t=u+1}^{v}\theta _{t})$
, respectively. Based on the previous chapter, it is known that
 $\beta _{S(1,j)}=0$
; therefore, angles in the cosine term of unbalanced components below the first row can be generally expressed as
 $(0-\sum _{t=u+1}^{v}\theta _{t})$
for
 $u\gt 1$
. To balance such components with a non-ground-connected spring, the components of the non-ground-connected spring need to have a
 $\pi$
difference between their angles in the cosine term and
 $(0-\sum _{t=u+1}^{v}\theta _{t})$
.
For a non-ground-connected spring
 $\mathrm{S}_{i,j}$
, the matrix components include
 $K_{i,j}^{S(i,j)},K_{i,v}^{S(i,j)},K_{u,j}^{S(i,j)}$
, and
 $K_{u,v}^{S(i,j)}$
for
 $u\lt i$
and
 $v\gt j$
, of which their angles in the cosine terms are
 $(\pi +\alpha _{S(i,j)}-\beta _{S(i,j)}-\sum _{t=i+1}^{j}\theta _{t})$
,
 $(\pi +\alpha _{S(i,j)}-\sum _{t=i+1}^{v}\theta _{t})$
,
 $(\!-\!\beta _{S(i,j)}-\sum _{t=u+1}^{j}\theta _{t})$
, and
 $(0-\sum _{t=u+1}^{v}\theta _{t})$
, respectively. Where
 $K_{u,v}^{S(i,j)}$
has the same angles as the unbalanced components, it cannot be used to balance but needs to be balanced by other springs. For
 $K_{i,j}^{S(i,j)},K_{i,v}^{S(i,j)}\;$
, and
 $K_{u,j}^{S(i,j)}$
, to have a
 $\pi$
difference with the unbalanced components that were remained by the ground-connected springs, the constraints of angles are listed as follows
 \begin{equation} \left(\pi +\alpha _{S\left(i,j\right)}-\beta _{S\left(i,j\right)}-\sum _{t=i+1}^{j}\theta _{t}\right)-\left(0-\sum _{t=i+1}^{j}\theta _{t}\right)=\pi \end{equation}
 \begin{equation} \left(\pi +\alpha _{S\left(i,j\right)}-\sum _{t=i+1}^{v}\theta _{t}\right)-\left(0-\sum _{t=i+1}^{v}\theta _{t}\right)=\pi \end{equation}
 \begin{equation} \left(\!-\!\beta _{S\left(i,j\right)}-\sum _{t=u+1}^{j}\theta _{t}\right)-\left(0-\sum _{t=u+1}^{j}\theta _{t}\right)=\pi \end{equation}
Equations (23a)–(23c) cannot be established at the same time. It is shown that the components
 $K_{i,j}^{S(i,j)},K_{i,v}^{S(i,j)}\;$
, and
 $K_{u,j}^{S(i,j)}$
cannot be used simultaneously to balance the unbalanced components remained by the ground-connected springs. With that said, a non-ground-connected spring is able to contribute at most two types of components that can be used for balancing. Here, we use
 $K_{i,j}^{S(i,j)}$
and
 $K_{i,v}^{S(i,j)}$
to balance. According to Eqs. (23a), (23b),
 \begin{equation} \left(\alpha _{S\left(i,j\right)},\beta _{S\left(i,j\right)}\right)=\left(0,0\right) \end{equation}
While
 $K_{i,j}^{S(i,j)}\;$
and
 $K_{u,j}^{S(i,j)}$
are used for balancing, according to Eqs. (23a), (23c),
 \begin{equation} \left(\alpha _{S\left(i,j\right)},\beta _{S\left(i,j\right)}\right)=\left(\pi,\pi \right) \end{equation}
The attachment angles in Eqs. (24a), (24b) are ideal attachment angles for non-ground-connected springs. Note that, according to Eqs. (23b), (23c), if
 $K_{i,v}^{S(i,j)}\;$
and
 $K_{u,j}^{S(i,j)}$
are chosen to balance, the spring is then attached with
 $(\alpha _{S(i,j)},\beta _{S(i,j)})=(0,\pi )$
. However, if a non-ground-connected spring
 $S_{i,j}$
with
 $(0,\pi )$
is used, the component
 $K_{i,j}^{S(i,j)}$
is remained and needs to be balanced. Still, it is required to be attached by another non-ground-connected spring
 $S_{i,j}^{\prime}$
with
 $(0,0)$
or
 $(\pi,\pi )$
. Accordingly, non-ground-connected spring with
 $(0,\pi )$
is not considered in this study.
There is a special case that needs to be considered. For a non-ground-connected spring attached between two adjacent links
 $\mathrm{S}_{i,i+1}$
, only one component,
 $K_{i,i+1}^{S(i,i+1)}$
, is contributed. That is, Eq. (23a) is the only constraint and
 $\mathrm{S}_{i,i+1}$
is required to be attached with angles that satisfy
 $\alpha _{S(i,i+1)}-\beta _{S(i,i+1)}=0$
.
For the non-ground-connected spring attached with
 $(\alpha _{S(i,j)},\beta _{S(i,j)})=(0,0)$
, the components
 $K_{i,j}^{S(i,j)}$
and
 $K_{i,v}^{S(i,j)}\;$
are used to balance while
 $K_{u,j}^{S(i,j)}$
and
 $K_{u,v}^{S(i,j)}$
are remained and need to be balanced. Similarly, for the non-ground-connected spring attached with
 $(\alpha _{S(i,j)},\beta _{S(i,j)})=(\pi,\pi )$
, the components
 $K_{i,v}^{S(i,j)}$
and
 $K_{u,v}^{S(i,j)}$
are remained as well and need to be balanced. To balance such components, another spring needs to be installed until all of them are balanced. Hence, the balancing condition in Eq. (19b) can be achieved.
Since the admissible spring attachment angles are found, the springs are also required to be attached in specific locations to ensure all the components from the forces can be fully offset. The installation of springs for a 3-DoF manipulator is developed in the following chapter.
4. Spring Installation of 3-DoF Serial Planar Manipulators for Balancing Constant Forces in Arbitrary Directions
4.1. Case 1: Balancing of a constant force applied on the end link
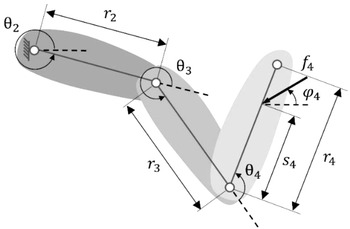
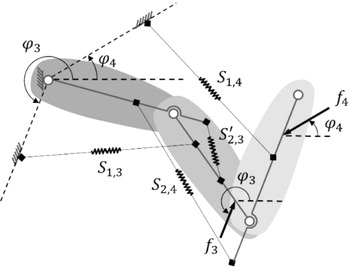
Figure 6 shows a 3-DoF manipulator with a constant force on the end link.
A 3-DoF manipulator with a constant force on the end link (the 4th link).

According to Eqs. (5), (6), the potential work of the force
 $f_{4}$
on the end link of the 3-DoF manipulator in Fig. 6 is
 \begin{equation} U_{f\left(4\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right]^{T}\left[\begin{array}{c@{\quad}c@{\quad}c@{\quad}c} 0 & W_{1,2}^{f\left(4\right)} & W_{1,3}^{f\left(4\right)} & W_{1,4}^{f\left(4\right)}\\[5pt] & 0 & 0 & 0\\[5pt] & \;& 0 & 0\\[5pt] \;& \;& \;& 0 \end{array}\right]\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right] \end{equation}
where
 \begin{equation} W_{1,4}^{f\left(4\right)}=\frac{f_{4}}{r_{1}}\frac{s_{4}}{r_{4}}\cos\!\left(\varphi _{4}-{\unicode[Arial]{x03B8}} _{2}-{\unicode[Arial]{x03B8}} _{3}-{\unicode[Arial]{x03B8}} _{4}\right) \end{equation}
 \begin{equation} W_{1,3}^{f\left(4\right)}=\frac{f_{4}}{r_{1}}\cos\!\left(\varphi _{4}-{\unicode[Arial]{x03B8}} _{2}-{\unicode[Arial]{x03B8}} _{3}\right) \end{equation}
 \begin{equation} W_{1,2}^{f\left(4\right)}=\frac{f_{4}}{r_{1}}\cos\!\left(\varphi _{4}-{\unicode[Arial]{x03B8}} _{2}\right) \end{equation}
To balance
 $W_{1,4}^{f(4)}$
, a spring,
 $S_{1,4}$
, is installed. According to Eq. (13), the spring’s energy is
 \begin{equation} U_{S\left(1,4\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right]^{T}\left[\begin{array}{c@{\quad}c@{\quad}c@{\quad}c} \mathrm{*} & K_{1,2}^{S\left(1,4\right)} & K_{1,3}^{S\left(1,4\right)} & K_{1,4}^{S\left(1,4\right)}\\[5pt] & \mathrm{*} & K_{2,3}^{S\left(1,4\right)} & K_{2,4}^{S\left(1,4\right)}\\[5pt] & \;& \mathrm{*} & K_{3,4}^{S\left(1,4\right)}\\[5pt] & \;& \;& \mathrm{*} \end{array}\right]\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right] \end{equation}
And according to Eq. (22), the ground-connected spring
 $S_{1,4}$
should be attached with angles
 $(\varphi _{4},0)$
. Therefore, from Eq. (12a), the component that corresponds to
 $W_{1,4}^{f(4)}$
is
 \begin{equation} K_{1,4}^{S\left(1,4\right)}=k_{S\left(1,4\right)}\frac{a_{S\left(1,4\right)}}{r_{1}}\frac{b_{S\left(1,4\right)}}{r_{4}}\cos\!\left(\pi +\varphi _{4}-{\unicode[Arial]{x03B8}} _{2}-{\unicode[Arial]{x03B8}} _{3}-{\unicode[Arial]{x03B8}} _{4}\right) \end{equation}
To fully balance
 $W_{1,4}^{f(4)}$
, that is when
 $K_{1,4}^{S(1,4)}+W_{1,4}^{f(4)}=0$
, comparing Eqs. (26a) and (28), the spring parameters of
 $S_{1,4}$
should satisfy
 \begin{equation} k_{S\left(1,4\right)}\frac{a_{S\left(1,4\right)}}{r_{1}}\frac{b_{S\left(1,4\right)}}{r_{4}}=\frac{f_{4}}{r_{1}}\frac{s_{4}}{r_{4}} \end{equation}
Also,
 $W_{1,3}^{f(4)}$
and
 $W_{1,2}^{f(4)}$
correspond to
 $K_{1,3}^{S(1,4)}$
and
 $K_{1,2}^{S(1,4)}$
, respectively. According to Eq. (12b),
 \begin{equation} K_{1,3}^{S\left(1,4\right)}=k_{S\left(1,4\right)}\frac{a_{S\left(1,4\right)}}{r_{1}}\cos\!\left(\pi +\varphi _{4}-{\unicode[Arial]{x03B8}} _{2}-{\unicode[Arial]{x03B8}} _{3}\right) \end{equation}
 \begin{equation} K_{1,2}^{S\left(1,4\right)}=k_{S\left(1,4\right)}\frac{a_{S\left(1,4\right)}}{r_{1}}\cos\!\left(\pi +\varphi _{4}-{\unicode[Arial]{x03B8}} _{2}\right) \end{equation}
Similarly, to fully balance
 $W_{1,3}^{f(4)}$
and
 $W_{1,2}^{f(4)}$
, comparing Eqs. (30a), (30b) with Eqs. (26b), (26c), the spring parameters of
 $S_{1,4}$
should satisfy
 \begin{equation} k_{S\left(1,4\right)}\frac{a_{S\left(1,4\right)}}{r_{1}}=\frac{f_{4}}{r_{1}} \end{equation}
When Eqs. (29), (31) are satisfied, the components
 $W_{1,4}^{f(4)}$
,
 $W_{1,3}^{f(4)}$
, and
 $W_{1,2}^{f(4)}$
are fully balanced by ground-connected spring
 $S_{1,4}$
with angles
 $(\varphi _{4},0)$
. However, the components
 $K_{2,3}^{S(1,4)}$
,
 $K_{2,4}^{S(1,4)}$
, and
 $K_{3,4}^{S(1,4)}$
are remained and need to be balanced by non-ground-connected springs, where
 \begin{equation} K_{2,3}^{S\left(1,4\right)}=k_{S\left(1,4\right)}\cos\!\left(\!-\!{\unicode[Arial]{x03B8}} _{3}\right) \end{equation}
 \begin{equation} K_{2,4}^{S\left(1,4\right)}=k_{S\left(1,4\right)}\frac{b_{S\left(1,4\right)}}{r_{4}}\cos\!\left(\!-\!{\unicode[Arial]{x03B8}} _{3}-{\unicode[Arial]{x03B8}} _{4}\right) \end{equation}
 \begin{equation} K_{3,4}^{S\left(1,4\right)}=k_{S\left(1,4\right)}\frac{b_{S\left(1,4\right)}}{r_{4}}\cos\!\left(\!-\!{\unicode[Arial]{x03B8}} _{4}\right) \end{equation}
To balance
 $K_{2,4}^{S(1,4)}$
, a non-ground-connected spring
 $S_{2,4}$
needs to be installed. According to Eqs. (24a), (24b),
 $S_{2,4}$
needs to be attached with angles
 $(0,0)$
or
 $(\pi,\pi )$
. The elastic energy of
 $S_{2,4}$
is
 \begin{equation} U_{S\left(2,4\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right]^{T}\left[\begin{array}{c@{\quad}c@{\quad}c@{\quad}c} * & 0 & 0 & 0\\[5pt] \;& * & K_{2,3}^{S\left(2,4\right)} & K_{2,4}^{S\left(2,4\right)}\\[5pt] \;& \;& * & K_{3,4}^{S\left(2,4\right)}\\[5pt] \;& \;& \;& * \end{array}\right]\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right] \end{equation}
If a non-ground-connected spring
 $S_{2,4}$
with
 $(\pi,\pi )$
is installed, the component that corresponds to
 $K_{2,4}^{S(1,4)}$
is
 \begin{equation} K_{2,4}^{S\left(2,4\right)}=k_{S\left(2,4\right)}\frac{a_{S\left(2,4\right)}}{r_{2}}\frac{b_{S\left(2,4\right)}}{r_{4}}\cos\!\left(\pi -{\unicode[Arial]{x03B8}} _{3}-{\unicode[Arial]{x03B8}} _{4}\right) \end{equation}
To fully balance
 $K_{2,4}^{S(1,4)}$
, the spring parameters of
 $S_{2,4}$
should satisfy
 \begin{equation} k_{S\left(2,4\right)}\frac{a_{S\left(2,4\right)}}{r_{2}}\frac{b_{S\left(2,4\right)}}{r_{4}}=k_{S\left(1,4\right)}\frac{b_{S\left(1,4\right)}}{r_{4}} \end{equation}
Also, the component that corresponds to
 $K_{3,4}^{S(1,4)}$
is
 \begin{equation} K_{3,4}^{S\left(2,4\right)}=k_{S\left(2,4\right)}\frac{b_{S\left(2,4\right)}}{r_{4}}\cos\!\left(\pi -{\unicode[Arial]{x03B8}} _{4}\right) \end{equation}
To fully balance
 $K_{3,4}^{S(1,4)}$
, the spring parameters of
 $S_{2,4}$
should satisfy
 \begin{equation} k_{S\left(2,4\right)}\frac{b_{S\left(2,4\right)}}{r_{4}}=k_{S\left(1,4\right)}\frac{b_{S\left(1,4\right)}}{r_{4}} \end{equation}
The components
 $K_{2,4}^{S(1,4)}$
and
 $K_{3,4}^{S(1,4)}$
are balanced by
 $S_{2,4}$
with
 $(\pi,\pi )$
. However, the component
 $K_{2,3}^{S(1,4)}$
, which cannot be balanced by
 $S_{2,4}$
, is still remained. In this case, the component of
 $S_{2,4}$
that corresponds to
 $K_{2,3}^{S(1,4)}$
is
 \begin{equation} K_{2,3}^{S\left(2,4\right)}=k_{S\left(2,4\right)}\frac{a_{S\left(2,4\right)}}{r_{2}}\cos\!\left(\!-\!{\unicode[Arial]{x03B8}} _{3}\right) \end{equation}
Comparing Eq. (38) with Eq. (32a), the angles in the cosine term are the same. Therefore,
 $K_{2,3}^{S(2,4)}$
cannot be used to offset
 $K_{2,3}^{S(1,4)}$
. It requires another non-ground-connected spring
 $S_{2,3}$
. The spring energy of
 $S_{2,3}$
is
 \begin{equation} U_{S\left(2,3\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right]^{T}\left[\begin{array}{c@{\quad}c@{\quad}c@{\quad}c} * & 0 & 0 & 0\\[5pt] \;& * & K_{2,3}^{S\left(2,4\right)} & 0\\[5pt] \;& \;& * & 0\\[5pt] \;& \;& \;& * \end{array}\right]\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right] \end{equation}
Spring
 $S_{2,3}$
is attached between two adjacent links. According to previous sections,
 $S_{2,3}$
should be attached with angles that satisfy
 $\alpha _{S(2,3)}-\beta _{S(2,3)}=0$
. The only component in the matrix is
 \begin{equation} K_{2,3}^{S\left(2,3\right)}=k_{S\left(2,3\right)}\frac{a_{S\left(2,3\right)}}{r_{2}}\frac{b_{S\left(2,3\right)}}{r_{3}}\cos\!\left(\pi -{\unicode[Arial]{x03B8}} _{3}\right) \end{equation}
Comparing Eq. (40) with Eqs. (32a), (38), the spring parameters of
 $S_{2,3}$
must satisfy
 \begin{equation} k_{S\left(2,3\right)}\frac{a_{S\left(2,3\right)}}{r_{2}}\frac{b_{S\left(2,3\right)}}{r_{3}}=k_{S\left(1,4\right)}+k_{S\left(2,4\right)}\frac{a_{S\left(2,4\right)}}{r_{2}} \end{equation}
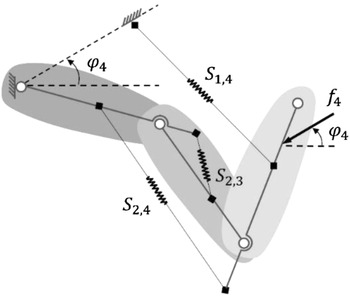
So far, the system is fully balanced, and an admissible spring installation is found. The installation of springs is shown in Fig. 7.
An admissible spring installation of a 3-DoF serial planar manipulator for balancing a constant force.

4.2. Case 2: Balancing multiple constant forces
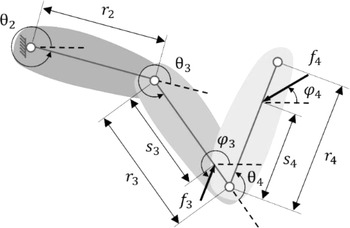
In case 2, there are multiple constant forces (
 $f_{3}$
and
 $f_{4}$
) applied on the manipulator as shown in Fig. 8:
A 3-DoF manipulator with multiple constant forces.

Similar to case 1, the potential work of
 $f_{4}$
is fully balanced by a ground-connected spring
 $S_{1,4}$
with angles
 $(\varphi _{4},0)$
. And the potential work of
 $f_{3}$
is
 \begin{equation} U_{f\left(3\right)}=\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right]^{T}\left[\begin{array}{c@{\quad}c@{\quad}c@{\quad}c} 0 & W_{1,2}^{f\left(3\right)} & W_{1,3}^{f\left(3\right)} & 0\\[5pt] & 0 & 0 & 0\\[5pt] & \;& 0 & 0\\[5pt] \;& \;& \;& 0 \end{array}\right]\left[\begin{array}{c} r_{1}\\[5pt] r_{2}\\[5pt] r_{3}\\[5pt] r_{4} \end{array}\right] \end{equation}
It requires a ground-connected spring
 $S_{1,3}$
with angles
 $(\varphi _{3},0)$
. To fully balance the components
 $W_{1,2}^{f(3)}$
and
 $W_{1,3}^{f(3)}$
, the spring parameters of
 $S_{1,3}$
should satisfy
 \begin{equation} k_{S\left(1,3\right)}\frac{a_{S\left(1,3\right)}}{r_{1}}\frac{b_{S\left(1,3\right)}}{r_{3}}=\frac{f_{3}}{r_{1}}\frac{s_{3}}{r_{3}} \end{equation}
and
 \begin{equation} k_{S\left(1,3\right)}\frac{a_{S\left(1,3\right)}}{r_{1}}=\frac{f_{3}}{r_{1}} \end{equation}
An admissible spring installation of a 3-DoF serial planar manipulator for balancing multiple constant forces.

(a) A planar 3-DoF grinding manipulator, (b) Spring attachment on a planar 3-DoF grinding manipulator.

Same as case 1, a non-ground-connected spring
 $S_{2,4}$
with
 $(\pi,\pi )$
is installed to balance the remaining components
 $K_{2,4}^{S(1,4)}$
and
 $K_{3,4}^{S(1,4)}$
. Yet the ground-connected spring
 $S_{1,3}$
also left a component
 \begin{equation} K_{2,3}^{S\left(1,3\right)}=k_{S\left(1,3\right)}\frac{b_{S\left(1,3\right)}}{r_{3}}\cos\!\left(\!-\!{\unicode[Arial]{x03B8}} _{3}\right) \end{equation}
Therefore, comparing with
 $S_{2,3}$
in case 1 which balances two components
 $K_{2,3}^{S(1,4)}$
and
 $K_{2,3}^{S(2,4)}$
,
 $S_{2,3}^{\prime}$
in case 2 is required to balance three components
 $K_{2,3}^{S(1,4)}$
,
 $K_{2,3}^{S(2,4)}$
and
 $K_{2,3}^{S(1,3)}$
. The constraints of spring parameters of
 $S_{2,3}^{\prime}$
are as follows:
 \begin{equation} k_{S\left(2,3\right)}^{\prime}\frac{a_{S\left(2,3\right)}^{\prime}}{r_{2}}\frac{b_{S\left(2,3\right)}^{\prime}}{r_{3}}=k_{S\left(1,4\right)}+k_{S\left(2,4\right)}\frac{a_{S\left(2,4\right)}}{r_{2}}+k_{S\left(1,3\right)}\frac{b_{S\left(1,3\right)}}{r_{3}} \end{equation}
The system of case 2 is fully balanced, and the installation of springs is shown in Fig. 9:
Spring parameters of the planar 3-DoFs grinding manipulator.

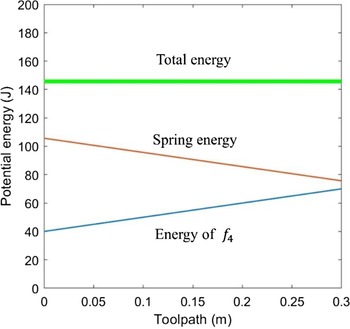
Energy of the planar 3-DoFs grinding manipulator during working process.

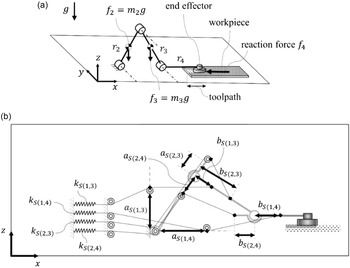
(a) A planar 3-DoF grinding manipulator working on the
 ${x}$
-
 ${z}$
plane, (b) Spring attachment on the grinding manipulator for balancing multiple forces.

5. An Illustrative Example: The Balancing of Resistance Force on a 3-DoFs Manipulator During Grinding Process
5.1. Balancing single resistance force
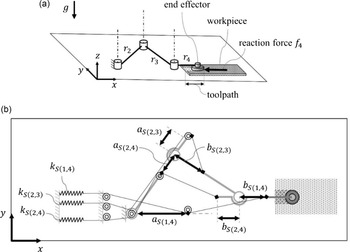
In Fig. 10(a), a 3-DoFs grinding manipulator is given as an example. Here, only the DoFs on the
 $x$
-
 $y$
plane are considered. Also, the grinding manipulator is simplified as a planar manipulator with revolute joints only. The manipulator is placed horizontally on the ground, and the direction of gravitational acceleration is assumed as the negative
 $z$
direction. Assuming that during operation, the manipulator works at a slow constant speed. And reaction force
 $f_{4}$
is assumed as a constant force applied on the end effector (the end of link 4) in the negative
 $x$
direction (
 $\varphi _{4}=0$
).
During the working process, the reaction force is usually resisted by actuators. When applying the balancing method in this study, the reaction force is resisted by the springs. Therefore, the method theoretically decreases the load of the actuators. To apply the spring installation shown in Fig. 7, the springs are attached on the manipulator as shown in Fig. 10(b). Here, to achieve ZFL springs in reality, we can refer to ref. [Reference Ou and Chen32], in which the springs are attached with cable-pully systems. With the arrangement of pullies, the distance between the two attachment points of a cable on the links equals the elongation of spring, and ZFL is thereby accomplished.
The dimensions of the 3-DoFs grinding manipulator are given as:
 $r_{2}=0.4\;(\mathrm{m})$
,
 $r_{3}=0.4\;(\mathrm{m})$
and
 $r_{4}=0.3\;(\mathrm{m})$
. Furthermore, the reaction force applied on the end effector (link 4) is a constant value
 $f_{4}=100\,(\mathrm{N})$
in
 $\varphi _{3}=0$
during operation. According to case 1 , to balance the reaction force
 $f_{4}$
, the constraints of springs’ parameters are Eqs. (29), (31), (35), (37) and (41). The spring parameters are found accordingly and are shown in Table I.
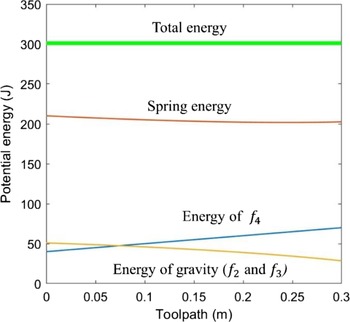
Figure 11 is the simulation of system energy during the grinding process. It shows that the total energy maintains a constant value, and theoretically, the spring-manipulator system is perfectly balanced.
5.2. Balancing gravity and resistance force
Figure 12(a) shows another example: the planar 3-DoF grinding manipulator works on the
 $x$
-
 $z$
plane. Since the gravitational acceleration is in the negative
 $z$
direction, besides the reaction force applied on the end effector, links 2 and 3 also bear their own gravity. There are three forces (
 $f_{2}=m_{2}g$
in
 $\varphi _{2}=\pi /2, f_{3}=m_{3}g$
in
 $\varphi _{3}=\pi /2\;\mathrm{and}\;f_{4}$
in
 $\varphi _{4}=0$
) that need to be balanced.
According to case 2 in Section 4, the reaction force
 $f_{4}$
in
 $\varphi _{4}=0$
is balanced by the ground-connected spring
 $S_{1,4}$
with angles
 $(0,0)$
. And the gravity
 $f_{2}$
and
 $f_{3}$
in
 $\varphi _{2}=\varphi _{3}=\pi /2$
can be balanced by another ground-connected spring
 $S_{1,3}$
with angles
 $(\pi /2,0)$
. The spring installation is shown in Fig. 12(b).
The constraints of the ground-connected springs are
 \begin{equation} k_{S\left(1,4\right)}\frac{a_{S\left(1,4\right)}}{r_{1}}\frac{b_{S\left(1,4\right)}}{r_{4}}=\frac{f_{4}}{r_{1}}\frac{s_{4}}{r_{4}} \end{equation}
 \begin{equation} k_{S\left(1,4\right)}\frac{a_{S\left(1,4\right)}}{r_{1}}=\frac{f_{4}}{r_{1}} \end{equation}
 \begin{equation} k_{S\left(1,3\right)}\frac{a_{S\left(1,3\right)}}{r_{1}}\frac{b_{S\left(1,3\right)}}{r_{3}}=\frac{m_{3}g}{r_{1}}\frac{s_{3}}{r_{3}} \end{equation}
 \begin{equation} k_{S\left(1,3\right)}\frac{a_{S\left(1,3\right)}}{r_{1}}=\frac{m_{2}g}{r_{1}}\frac{s_{3}}{r_{3}}+\frac{m_{3}g}{r_{1}} \end{equation}
Spring parameters for balancing of multiple forces.

Energy of a planar 3-DoF grinding manipulator during working process in which gravity and reaction force are balanced by springs.

And the non-ground-connected springs,
 $S_{2,4}$
with
 $(\pi,\pi )$
and
 $S_{2,3}$
with angles satisfying
 $\alpha _{S(2,3)}-\beta _{S(2,3)}=0$
, are used to balance the components that are remained by the ground-connected springs. The constraints of the non-ground-connected springs are as follows.
 \begin{equation} k_{S\left(2,4\right)}\frac{a_{S\left(2,4\right)}}{r_{2}}\frac{b_{S\left(2,4\right)}}{r_{4}}=k_{S\left(1,4\right)}\frac{b_{S\left(1,4\right)}}{r_{4}} \end{equation}
 \begin{equation} k_{S\left(2,4\right)}\frac{b_{S\left(2,4\right)}}{r_{4}}=k_{S\left(1,4\right)}\frac{b_{S\left(1,4\right)}}{r_{4}} \end{equation}
 \begin{equation} k_{S\left(2,3\right)}\frac{a_{S\left(2,3\right)}}{r_{2}}\frac{b_{S\left(2,3\right)}}{r_{3}}=k_{S\left(1,4\right)}+k_{S\left(1,3\right)}\frac{b_{S\left(1,3\right)}}{r_{3}}+k_{S\left(2,4\right)}\frac{a_{S\left(2,4\right)}}{r_{2}} \end{equation}
From the constraints, the springs’ parameters on the manipulator are shown in Table II.
And the simulation of the system’s energy is shown in Fig. 13.
Note that, in real life application, the reaction force applied on the end effector of grinding may not always be a constant value. Therefore, the spring-manipulator system can only be partially balanced. Though it might not be free of limitations, the methodology in this paper decreases the loading of actuators by using springs to compensate reaction forces.
6. Conclusion
The paper developed spring-balanced planar serial 3-DoF manipulators with revolute joints only for constant forces in arbitrary directions. The energy is expressed in quadratic form, which shows the balancing conditions clearly. In quadratic form, the components are function of springs’ stiffness and attachment points. To ensure the springs are used for balancing, they have to be attached at specific angles. The ideal spring attachment angles to balance constant forces in arbitrary directions are found. That is, the ground-connected springs are attached with
 $(\varphi _{j},0)$
, where
 $\varphi _{j}$
is the direction of the force; and the non-ground-connected springs are attached with
 $(0,0)$
or
 $(\pi,\pi )$
. Comparing with the spring-gravity balanced manipulator proposed in the past research [Reference Juang and Chen18], balancing gravity and force in arbitrary directions required two spring systems, which are differed in spring attachment angles.
Besides the angles, the springs must be installed at specific locations based on the balancing conditions. The spring installation for balanced 3-DoF manipulators is explored accordingly. Finally, an example of the balancing of resistance force on a planar 3-DoF manipulator during grinding process is given, and the simulation shows that the manipulator can be perfectly balanced by the method. In summary, this paper for the first time discusses the balancing of a manipulator with constant forces in arbitrary directions, which expands the force balancing theory to broader application.
Acknowledgment
The authors gratefully acknowledge the support of the Ministry of Science and Technology (MOST).
Author contributions
The paper was written with the contributions of all authors. CWJ and CSJ developed the methodology. CWJ completed the simulation. CWJ wrote the paper. DZC guided the research and reviewed the paper. All authors have worked proportionally and given approval to the present research.
Financial support
This research has been supported by the Ministry of Science and Technology (MOST), Taiwan (grant no. 109-2221-E-002-002-MY3)
Conflicts of interest
The authors declare no conflicts of interest exist.
Ethical approval
Not applicable.