


1. Introduction
Parallel mechanisms (PMs) in machining, packaging assembly, aerospace, medicine, and many other fields, more and more parallel robots have been applied, of which the more successful applications include motion simulators [Reference Petrasinovic, Grbovic and Petrasinovic1], fast gripping and handling robots [Reference Pillai and Ganesan2], entertainment equipment, large structural components of multi-axis machining equipment [Reference Huang, Dong, Liu, Sun and Chetwynd3], satellite radar docking, aircraft parts assembly [Reference Li, Deng, Zeng and Huang4–Reference Chu and Huang6], etc. In the paper, P, R, S, U, and C represent prismatic, revolute, spherical, universal, and cylindrical joints, respectively.
Currently, according to the relationship between the input number N of the mechanism and the degree-of-freedom (DOF) M, the main driving methods for PMs include traditional driving [Reference Zhang, Xu and Yao7–Reference Gallardo-Alvarado9] (N= M), redundant driving [Reference Liu, Tao, Fan, Wang, Jing and Tan10] (N> M), and underactuated [Reference Moosavian, Xi and Hashemi11–Reference Shen, Zhu, Zhang, Deng and Dai15] (N< M). Other scholars have proposed new PMs consisting of one constrained branch and many drive branches. Reference [Reference Blanco and Rodriguez16] proposed the 3UPS-PU parallel mechanism consisting of four branches. The PU is the constrained branch, and the 3UPS is the unconstrained drive branch. Reference [Reference Chen, Wang, Niu, Wang and Sun17] proposed the 5UPS-PRPU PM, which consists of five unconstrained drive branches UPS and one unconstrained drive branch PRPU. Reference [Reference Shan and Cheng18] proposed the 2(3PUS+S) PM with fewer inputs and more platform outputs, in which multiple identical PMs are arranged longitudinally to share a prismatic joint. However, few current studies have centralized the drive management of parallel mechanisms.
As the industry develops, there is an increasing demand for fewer inputs and more outputs, such as solar trackers [Reference Wu, Wang and Chang19], antennas, and recreational facilities [Reference Chen, Chen, Gao, Zhao, Zhao and Li20]. In the aero-engine, as many as hundreds of blades/propellers output pieces of the attitude angle of the synchronized regulation may, on occasion, need to be used in the form of fewer input array output drives. By separating the constraints and drives of parallel mechanism branches, and consolidating all drives into a single branch for centralized management, it is possible to achieve synchronized array output of multiple moving platforms using fewer drives.
In this study, a new type of parallel mechanism with separate drive and constraint is innovatively proposed. The 3-DOF PMs are considered a particularly important type among various low-DOF PMs. To obtain a new 3DOFs PM, configuration synthesis becomes the most effective way. A series of 3-DOF PMs with separated drive and constraint are synthesized, and the mechanism with less input array output is further proposed. The novel mechanism realizes the separation of drive and constraint compared with the traditional PM, and the drive is easier to centrally manage, greatly reducing the number of drives and making it easier to maintain and repair in the future, making it suitable for array output.
2. The Type Synthesis of New PMs of 3T, 2T1R, and 2R1T
Adding a driving branch to the original PM ensures that its driving force wrench system and the constraint wrench system of the original parallel mechanism are linearly independent. 3-DOF PMs are relatively important among low-DOF PM types. Therefore, a series of 3-DOF PMs are synthesized using the type synthesis method.
2.1. Type synthesis method of a new PM
Figure 1(a) shows that traditional PMs integrate drives and constraints. As shown in Figure 1(b), the drives and constraints of the new PMs are separated, and the drive is concentrated on one branch, making it easier to centralize the drives.
Difference between traditional and novel PMs.

Based on the original parallel mechanism, add one active drive branch, concentrating all drives of the original parallel mechanism onto this active drive branch. Therefore, by adding an actively driven unconstrained branch, it ensures that driving force wrenches and constraint force wrenches are linearly independent. The new parallel mechanism can achieve the motion of the original parallel mechanism.
As shown in Figure 2, the synthesis of the new parallel configuration first adopts the screw theory to synthesize the original PM, then adds an unconstrained branch and ensures that the driving force wrenches and the constraint force wrenches are linearly independent. Finally, a feasible active drive branch is constructed.
Type synthesis method of the new PM.

Defining constraint couples A as:
 \begin{equation} A\ : \left\{\begin{array}{l} \boldsymbol{$}_{\mathrm{1}t}=\left[\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 0 & 0 & ; & 1 & 0 & 0 \end{array}\right]\\[5pt] \boldsymbol{$}_{\mathrm{2}t}=\left[\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 0 & 0 & ; & 0 & 1 & 0 \end{array}\right]\\[5pt] \boldsymbol{$}_{\mathrm{3}t}=\left[\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 0 & 0 & ; & 0 & 0 & 1 \end{array}\right] \end{array}\right. \end{equation}
Defining constraint forces B as:
 \begin{equation} B\ :\left\{\begin{array}{l} \boldsymbol{$}_{\mathrm{1}\mathit{r}}=\left[\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 1 & 0 & 0 & ; & 0 & 0 & 0 \end{array}\right]\\[5pt] \boldsymbol{$}_{\mathrm{2}r}=\left[\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 1 & 0 & ; & 0 & 0 & 0 \end{array}\right]\\[5pt] \boldsymbol{$}_{\mathrm{3}r}=\left[\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 0 & 1 & ; & 0 & 0 & 0 \end{array}\right] \end{array}\right. \end{equation}
Suppose the DOF of the new pTqR PM is m= p+ q (p, q = 1,2,3). The constraint wrenches of the original PMs can be represented as
 \begin{equation} \left\{\begin{array}{l} \boldsymbol{$}_{ir}=\left[\begin{array}{l} \textit{arbitrarily}\left(B,3-p\right)\\ \textit{arbitrarily}\left(A,3-q\right) \end{array}\right]\\[8pt] \boldsymbol{$}_{2R1T}=\left[\begin{array}{l} \textit{arbitrarily}\left(B,2\right)\\ \textit{arbitrarily}\left(A,1\right) \end{array}\right] \textrm{P} \left[\textit{arbitrarily}\left(B,3\right)\right] \end{array}\right. \end{equation}
where
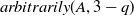 $\textit{arbitrarily}(A,3-q)$
represents taking any 3-q from A and
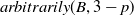 $\textit{arbitrarily}(B,3-p)$
represents taking any 3-p from B.
According to the principles of screw theory, the addition of an active driving branch should ensure that the constraint wrenches of the original PM and the driving force wrenches are linearly independent. It can be expressed as
 \begin{equation} rank\left[\begin{array}{l} \boldsymbol{$}_{ir}\\[5pt] \boldsymbol{$}_{if} \end{array}\right]=6 \end{equation}
where
 $\boldsymbol{$}_{ir}$
represents the constraint wrenches of the original PM;
 $\boldsymbol{$}_{if}$
represents the transmission force screw;
 $rank$
represents the rank of matrix.
Based on the aforementioned synthesis methods, a series of new PMs with 3-DOF can be synthesized. For low-DOF PMs, the output degrees of freedom of the moving platform are determined by the structural constraints imposed by the branches. Therefore, analyzing the constraint forces and constraint couples imposed on the moving platform by different branches can be used to determine the degrees of freedom of the PM. According to the screw theory, the criteria for determining the constraint forces and constraint couplings according to the branch chain composition are as follows [Reference Zhang, Zheng, Wei, Wu, Xu and Zhao21]:
-
(1) The constraint forces are coplanar with all R joints in the branch and perpendicular to the P joints.
-
(2) The constraint couple is oriented perpendicular to all R joints within the branch.
2.2. Type synthesis of 3T parallel mechanism
In 3T PMs, three constraint couples need to be provided. When one branch provides a constraint couple in one direction, the other two branches provide constraint couples in the other two directions, respectively.
From the above analysis, it can be concluded that the 3T PMs are composed of branches with constraints such as 3CPR, 3RRC, and 3RPC and drive branches such as RRPS, RRRS, PRRS, RPRS, and PPPS. Thereby, a series of new 3T PMs can be constructed, such as 3RPC-PPPS, 3RRC-PPPS, 3RPC-PPPS, 3RRC-PPPS, 3RRC-RRPS, 3RPC-RRPS, etc. The following figure shows some typical mechanisms (as shown in Figure 3).
Type synthesis of PMs with 3T.

2.3. Type synthesis of 2R1T parallel mechanism
The 2R1T PMs must provide two constraint forces and one constraint couple or three constraints.
From the above analysis, it can be concluded that the 2R1T PMs consist of the branch with constraints such as 3RRS, 3RPS, 2RPS-SPR, RRC-RC-UPS, 2RPU-UPR, and PRC-PU-UPS and drive branches such as PPPU, RRPS, RRRS, PRRS, RPRS, and PPPS. Thereby, a series of new 2R1T PMs can be constructed, such as 3RPS-PPPS, 2RPS-SPR-PPPS, 2RPU-UPR-PPPS, RPU-PU-UPS-PPPS, RRC-RC-PPPS, etc. The following figure shows some typical mechanisms (as shown in Figure 4).
Type synthesis of PMs with 2R1T.

2.4. Type synthesis of 2T1R parallel mechanism
The 2T1R PMs need to provide two constraint couples and one constraint force.
From the above analysis, it can be concluded that the 2T1R PMs consist of the branch with constraints such as planar mechanism: UPS-RPS-RPU, UPS-RPS-RRR, 2UPR-UPS, 2RRR-UPS, 2UPS-RRP, 2UPS-PRR and drive branch such as PPRS. Thereby, a series of new 2T1R PMs can be constructed, such as UPS-RPS-RPU-PPRS, UPS-RPS-RRR-PPRS, 2UPR-UPS-PPRS, 2RRR-UPS-PPRS, 2UPS-RRP-PPRS, 2UPS-PRR-PPRS, etc. The following figure shows some typical mechanisms (as shown in Figure 5).
Type synthesis of PMs with 2T1R.

2.5. Type synthesis of 3R parallel mechanism
The 3R PMs need to provide three constraint forces.
From the above analysis, it can be concluded that the 3R PMs consist of the branches with constraints such as RRS-S-2UPS, and RPS-S-2UPS and drive branches such as PPPS. Thereby, a series of new 3R PMs can be constructed, such as 3RRR-S-PPPS, RPS-S-2UPS-PPPS, RRS-S-2UPS-PPPS, etc. The following figure shows some typical mechanisms (as shown in Figure 6).
Type synthesis of PMs with 3R.

2.6. The application of the new PM in the platform of few inputs and multiple outputs
Through the above type of synthesis, it can be found that it is better to manage the drive branches centrally when the drive branches are PPPS. The mechanism with fewer inputs and multiple outputs is constructed, with parallel constraint branches connected to fixed platform 1 and intermediate branches connected to fixed platform 2. The drive branch is connected to fixed platform 2, as shown in Figure 7.
Type synthesis of PMs with few inputs and multiple outputs.

3. Kinematics Analysis of 3RRS/PPPS PMs
The inverse solution of the 3RRS/PPPS mechanism is solved using the closed-loop vector method. The complete Jacobian matrix of the mechanism has been established, and the static equilibrium equation is derived using the principle of virtual work. The mechanism’s motion and force transmission performance are analyzed using screw theory. Matlab and Adams are used to verify the accuracy of the mechanism’s fewer inputs array output.
3.1. Inverse solution of 3RRS/PPPS PMs
The 3RRS/PPPS PM is shown in Figure 8(a). 3nRRS/PPPS PM comprises n 3RRS/PPPS PMs and shares a PPPS drive branch, as shown in Figure 8(b). The fixed platform is connected to the moving platform by three RRS branches and 1 PPPS branch connecting the centers of the moving and fixed platforms. The three RRS branches are connected to fixed platform 1, and the PPPS branch is connected to fixed platform 2. The three prismatic joints of the PPPS branch are oriented in the x, y, and z directions of the fixed coordinate system.
PM with constraint and drive separation.

The fixed coordinate system
 $O-xyz$
is established that the x-axis is parallel to
B
1
B
2, y-axis along
OB
3, and the z-axis is perpendicular to the B
1
B
2
B
3 plane. The moving coordinate system
 $P-x_{1}y_{1}z_{1}$
can be constructed in the same way.
The attitude of the moving coordinate system to the fixed coordinate system can be expressed by the Z-Y-X Euler angle
 $(\alpha, \beta, \gamma )$
.
 ${{}_{P\!\!\!}}^{O}{\boldsymbol{R}}{}$
can be represented as:
 \begin{equation} \begin{array}{l} {{}_{P\!\!\!}}^{O}\boldsymbol{R}{}=\boldsymbol{R}\left(z,\alpha \right)\boldsymbol{R}\left(y,\beta \right)\boldsymbol{R}\left(x,\gamma \right)\\ =\left[\begin{array}{c@{\quad}c@{\quad}c} c\alpha c\beta & \mathit{c}\mathit{\alpha }s\beta s\gamma -s\alpha c\gamma & \mathit{c}\mathit{\alpha }s\beta c\gamma +s\alpha s\gamma \\[2pt] s\alpha c\beta & \mathit{s}\mathit{\alpha }s\beta s\gamma +c\alpha c\gamma & \mathit{s}\mathit{\alpha }s\beta c\gamma -c\alpha s\gamma \\[2pt] -s\beta & c\beta s\gamma & c\beta c\gamma \end{array}\right] \end{array} \end{equation}
where c and s represent cos and sin, respectively.
The coordinates of the joints of the moving and fixed platforms can be expressed as:
 \begin{equation} \begin{array}{l} {}^{P}\boldsymbol{A}{_{1}^{}}=\left[\frac{\sqrt{3}}{2}r,-\frac{r}{2},0\right]^{T}\begin{array}{ll} & \end{array}{}^{P}\boldsymbol{A}{_{2}^{}}=\left[-\frac{\sqrt{3}}{2}r,-\frac{r}{2},0\right]^{T}\\[5pt] {}^{P}\boldsymbol{A}{_{3}^{}}=\left[0,r,0\right]^{T}\begin{array}{l} \end{array}\boldsymbol{B}_{1}=\left[\frac{\sqrt{3}}{2}R,-\frac{R}{2},0\right]^{T}\begin{array}{l} \end{array}\\[5pt] \boldsymbol{B}_{2}=\left[-\frac{\sqrt{3}}{2}R,-\frac{R}{2},0\right]^{T}\begin{array}{l} \end{array}\boldsymbol{B}_{3}=\left[0,R,0\right]^{T}\begin{array}{l} \end{array}\boldsymbol{P}=\left[P_{x},P_{y},P_{z}\right]^{T} \end{array} \end{equation}
where
 ${}^{P}\boldsymbol{A}{_{i}^{}}$
and
 $\boldsymbol{B}_{i}$
(i = 1,2,3) represent coordinates in a fixed coordinate system.
The Eq. (5) can be expressed as
 \begin{equation} {{}_{P\!\!\!}}^{O}\boldsymbol{R}{}=\left[\begin{array}{c@{\quad}c@{\quad}c} T_{11} & T_{12} & T_{13}\\ T_{21} & T_{22} & T_{23}\\ T_{31} & T_{32} & T_{33} \end{array}\right] \end{equation}
The A i coordinates can be expressed in the fixed coordinate system as:
 \begin{equation} \boldsymbol{q}_{i}={}^{O}\boldsymbol{A}{_{i}^{}}={{}_{P\!\!\!}}^{O}\boldsymbol{R}\; {}^{P}\boldsymbol{A}{_{i}^{}}+\boldsymbol{P} \end{equation}
Equations (6), (7), (8) can be organized as:
 \begin{equation} \boldsymbol{q}_{i}=\left[\begin{array}{l} T_{11}S_{ix}+T_{12}S_{iy}+T_{13}S_{iz}+P_{x}\\[5pt] T_{21}S_{ix}+T_{22}S_{iy}+T_{23}S_{iz}+P_{Y}\\[5pt] T_{31}S_{ix}+T_{32}S_{iy}+T_{33}S_{iz}+P_{Z} \end{array}\right] \end{equation}
The three branched chains can only move in the
 $\unicode{x1D6FA} _{\mathrm{1}}$
(A
1
B
1
OP plane),
 $\unicode{x1D6FA} _{\mathrm{2}}$
(A
3
B
3
OP plane), and
 $\unicode{x1D6FA} _{\mathrm{3}}$
(A
2
B
2
OP plane) planes because of the constraints of the RRS branches, as shown in Figure 8(a).
Therefore, the constraint relationships can be expressed as:
 \begin{equation} \begin{array}{l} q_{1y}=-\frac{\sqrt{3}}{3}q_{1x}\\[5pt] q_{2y}=\frac{\sqrt{3}}{3}q_{2x}\\[5pt] q_{3x}=0 \end{array} \end{equation}
The accompanying motion can be calculated by Eqs. (7), (9), and (10):
 \begin{equation} \begin{array}{l} P_{x}=-r\left(\mathit{\cos }\mathit{\alpha }\sin \beta \sin \gamma -\sin \alpha \cos \gamma \right)\\[3pt] P_{y}=-\frac{r}{2}\left(\mathit{\sin }\mathit{\alpha }\sin \beta \sin \gamma \right)\\[3pt] \alpha =-\arctan \left(\frac{\sin \beta \sin \gamma }{\cos \beta\, +\, \cos \gamma }\right) \end{array} \end{equation}
Therefore, when
 $(\beta, \gamma )$
is known, the accompanying motion
 $(P_{x},P_{y},\alpha )$
of the mechanism can be obtained.
Closed-loop vector method.

The vector diagram in Figure 9,
 $\boldsymbol{E}\boldsymbol{A}_{4}$
can be represented as:
 \begin{equation} \boldsymbol{EF}+\boldsymbol{FH}+\boldsymbol{H}\boldsymbol{A}_{4}=\boldsymbol{E}\boldsymbol{A}_{4} \end{equation}
where
 $\boldsymbol{x}, \boldsymbol{y}$
and
 $\boldsymbol{z}$
represent the unit vectors of each the PPPS branches.
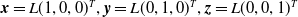 $\boldsymbol{x}=L(1,0,0)^{T}, \boldsymbol{y}=L(0,1,0)^{T}, \boldsymbol{z}=L(0,0,1)^{T}$
, where l
x
, l
y
, and l
z
represent the module length of the branch in (x, y, z) three directions.
 \begin{equation*} \begin{array}{l} \boldsymbol{EF}=l_{y}\cdot \boldsymbol{y}\\\boldsymbol{FH}=l_{x}\cdot \boldsymbol{x}\\ \boldsymbol{H}\boldsymbol{A}_{4}=l_{z}\cdot \boldsymbol{z}\\ \boldsymbol{E}\boldsymbol{A}_{4}=\boldsymbol{O}\boldsymbol{A}_{4}-\boldsymbol{OE}\\ \boldsymbol{O}\boldsymbol{A}_{4}=\boldsymbol{P}+{{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\times {}^{P}\left(\boldsymbol{P}\boldsymbol{A}_{4}\right) \end{array} \end{equation*}
The coordinates of A 4 point can be expressed as:
 \begin{equation} \left[\begin{array}{l} \Delta l_{x}\\[2pt] \Delta l_{y}\\[2pt] \Delta l_{z} \end{array}\right]=\left[\begin{array}{l} l_{x}-l_{x0}\\[2pt] l_{y}-l_{z0}\\[2pt] l_{z}-l_{z0} \end{array}\right] \end{equation}
where l x0, l y0, and l z0 represent three drivers’ initial lengths.
When the pose
 $(P_{x},P_{y},P_{z},\alpha, \beta, \gamma )$
of the moving platform is known, the amount of change in the drive branch can be obtained through Eq. (13).
3.2. Velocity analysis of 3RRS/PPPS PM
3.2.1. Driving Jacobian matrix
The speed of A 4 point on the moving platform is shown:
 \begin{equation} \boldsymbol{v}_{{A_{4}}}=\boldsymbol{v}_{p}+\boldsymbol{\omega }\times {{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4} \end{equation}
where
 $\boldsymbol{v}_{{A_{4}}}$
represents the moving platform A
4 point’s velocity;
 $\boldsymbol{v}_{p}$
represents the moving platform reference P point’s velocity;
 $\boldsymbol{\omega }$
represents the moving platform’s angular velocity;
 $\boldsymbol{p}\boldsymbol{A}_{4}$
represents coordinates of A
4 in the moving coordinate system.
Eq. (14) with simultaneous dot product
 $\boldsymbol{n}_{i}$
on both sides is expressed as:
 \begin{align}\begin{split} \dot{q}_{i} & =\boldsymbol{v}_{{A_{4}}}\cdot \boldsymbol{n}_{i}=\boldsymbol{v}_{p}\cdot \boldsymbol{n}_{i}+\boldsymbol{\omega }\times {{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4}\cdot \boldsymbol{n}_{i}\\& =\boldsymbol{v}_{p}\cdot \boldsymbol{n}_{i}+{{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4}\times \boldsymbol{n}_{i}\cdot \boldsymbol{\omega }\left(i=1,2,3\right) \end{split}\end{align}
where
 $\boldsymbol{n}_{1}=[\begin{array}{l@{\quad}l@{\quad}l} 1 & 0 & 0 \end{array}]^{T}, \boldsymbol{n}_{2}=[\begin{array}{l@{\quad}l@{\quad}l} 0 & 1 & 0 \end{array}]^{T}, \boldsymbol{n}_{3}=[\begin{array}{l@{\quad}l@{\quad}l} 0 & 0 & 1 \end{array}]^{T}$
.
The matrix of the above Eq. (15) can be expressed as:
 \begin{equation} \left(\begin{array}{l} \dot{q}_{1}\\[3pt] \dot{q}_{2}\\[3pt] \dot{q}_{3} \end{array}\right)=\left(\begin{array}{l@{\quad}l} {\boldsymbol{n}_{1}}^{T} & \left({{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4}\times \boldsymbol{n}_{1}\right)^{T}\\[3pt] {\boldsymbol{n}_{2}}^{T} & \left({{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4}\times \boldsymbol{n}_{2}\right)^{T}\\[3pt] {\boldsymbol{n}_{3}}^{T} & \left({{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4}\times \boldsymbol{n}_{3}\right)^{T} \end{array}\right)\cdot \left(\begin{array}{l} \boldsymbol{v}_{p}\\[3pt] \boldsymbol{\omega } \end{array}\right) \end{equation}
Eq. (16) can be expressed as:
 \begin{equation} \dot{q}=\boldsymbol{J}_{a}\cdot \boldsymbol{V} \end{equation}
where
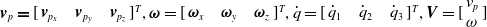 $\boldsymbol{v}_{p}\boldsymbol{=}[\begin{array}{l@{\quad}l@{\quad}l} \boldsymbol{v}_{{p_{x}}} & \boldsymbol{v}_{{p_{y}}} & \boldsymbol{v}_{{p_{z}}} \end{array}]^{T}, \boldsymbol{\omega }=[\begin{array}{l@{\quad}l@{\quad}l} \boldsymbol{\omega }_{x} & \boldsymbol{\omega }_{y} & \boldsymbol{\omega }_{z} \end{array}]^{T}, \dot{q}=[\begin{array}{l@{\quad}l@{\quad}l} \dot{q}_{1} & \dot{q}_{2} & \dot{q}_{3} \end{array}]^{T}, \boldsymbol{V}=[\begin{array}{l} v_{p}\\ \omega \end{array}]$
,
J
a
represents the driving Jacobian matrix of 3 × 6 [Reference Wang, Chen, Liu, Huang, Feng and Tian22, Reference Zhang, Yang and Mu23].
 \begin{equation*} \boldsymbol{J}_{a}=\left(\begin{array}{l@{\quad}l} {\boldsymbol{n}_{1}}^{T} & \left({{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4}\times \boldsymbol{n}_{1}\right)^{T}\\ {\boldsymbol{n}_{2}}^{T} & \left({{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4}\times \boldsymbol{n}_{2}\right)^{T}\\ {\boldsymbol{n}_{3}}^{T} & \left({{}_{P\!\!\!}}^{O}\boldsymbol{R}{}\cdot \boldsymbol{p}\boldsymbol{A}_{4}\times \boldsymbol{n}_{3}\right)^{T} \end{array}\right) \end{equation*}
3.2.2. Constraint jacobian matrix
The instantaneous motion wrench of the moving platform is expressed in the moving coordinate system:
 \begin{equation} \boldsymbol{$}_{p}=\sum _{j=1}^{3}\omega _{j,i}\boldsymbol{$}_{j,i}\qquad (i=1,2,3) \end{equation}
where
 $\omega _{j,i}$
represents the angular velocity of the jth joint of the ith branch;
 $\boldsymbol{$}_{j,i}$
represents the unit screw of the jth joint of the ith branch.
 \begin{gather*} \boldsymbol{$}_{1,i}=\left[\begin{array}{c} \boldsymbol{s}_{1,i}\\ \boldsymbol{s}_{1,i}\times \boldsymbol{B}_{i}\boldsymbol{p}{} \end{array}\right]^{T} \boldsymbol{$}_{1,i}=\left[\begin{array}{c} \boldsymbol{s}_{2,i}\\ \boldsymbol{s}_{2,i}\times \boldsymbol{C}_{i}\boldsymbol{p} \end{array}\right]^{T} \boldsymbol{$}_{3,i}=\left[\begin{array}{c} \boldsymbol{s}_{3,i}\\ \boldsymbol{s}_{3,i}\times \boldsymbol{A}_{i}\boldsymbol{p} \end{array}\right]^{T} \boldsymbol{$}_{4,i}=\left[\begin{array}{c} \boldsymbol{s}_{4,i}\\ \boldsymbol{s}_{4,i}\times \boldsymbol{A}_{i}\boldsymbol{p} \end{array}\right]^{T} \boldsymbol{$}_{5,i}=\left[\begin{array}{c} \boldsymbol{s}_{5,i}\\ \boldsymbol{s}_{5,i}\times \boldsymbol{A}_{i}\boldsymbol{p} \end{array}\right]^{T}\\ \boldsymbol{$}_{p}=\left[\begin{array}{c} \boldsymbol{\omega }\\ \boldsymbol{v}_{p} \end{array}\right]^{T} \end{gather*}
The constraint anti-screw of the RRS can be expressed as:
 \begin{equation} \boldsymbol{$}_{i}^{r}=\left[\begin{array}{c} \boldsymbol{s}_{1,i}\\ \boldsymbol{s}_{1,i}\times \boldsymbol{A}_{i}\boldsymbol{p}{} \end{array}\right]^{T} \end{equation}
The reciprocal product of both sides of Eq. (18) with Eq. (19), respectively, can be obtained:
 \begin{equation} \left(\begin{array}{l@{\quad}l} {\boldsymbol{s}_{1,1}}^{T} & \left(\boldsymbol{s}_{1,1}\times \boldsymbol{A}_{1}\boldsymbol{p}{}\right)^{T}\\[3pt] {\boldsymbol{s}_{2,1}}^{T} & \left(\boldsymbol{s}_{2,1}\times \boldsymbol{A}_{2}\boldsymbol{p}{}\right)^{T}\\[3pt] {\boldsymbol{s}_{3,1}}^{T} & \left(\boldsymbol{s}_{3,1}\times \boldsymbol{A}_{3}\boldsymbol{p}{}\right)^{T} \end{array}\right)\cdot \left(\begin{array}{l} \boldsymbol{v}_{p}\\[3pt] \boldsymbol{\omega } \end{array}\right)=\left(\begin{array}{l} 0\\[3pt] 0\\[3pt] 0 \end{array}\right) \end{equation}
Eq. (20) can be expressed as:
 \begin{equation} \boldsymbol{J}_{c}\cdot \boldsymbol{V}=0 \end{equation}
where
 $\boldsymbol{J}_{c}=\left(\begin{array}{l@{\quad}l} {\boldsymbol{s}_{1,1}}^{T} & (\boldsymbol{s}_{1,1}\times \boldsymbol{A}_{1}\boldsymbol{p}{})^{T}\\[5pt] {\boldsymbol{s}_{2,1}}^{T} & (\boldsymbol{s}_{2,1}\times \boldsymbol{A}_{2}\boldsymbol{p}{})^{T}\\[5pt] {\boldsymbol{s}_{3,1}}^{T} & (\boldsymbol{s}_{3,1}\times \boldsymbol{A}_{3}\boldsymbol{p}{})^{T} \end{array}\right)$
represents the constraint Jacobian matrix of 3 × 6.
Eqs. (17) and Eq. (21) can be expressed as:
 \begin{equation} \boldsymbol{J}\cdot \left(\begin{array}{l} \boldsymbol{v}_{p}\\[5pt] \boldsymbol{\omega } \end{array}\right)=\boldsymbol{V}_{l} \end{equation}
where
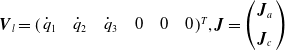 $\boldsymbol{V}_{l}=(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} \dot{q}_{1} & \dot{q}_{2} & \dot{q}_{3} & 0 & 0 & 0 \end{array})^{T}, \boldsymbol{J}=\left(\begin{array}{l} \boldsymbol{J}_{a}\\[5pt] \boldsymbol{J}_{c} \end{array}\right)$
.
Therefore, the complete Jacobi matrix can be obtained. A mapping between the speed of the moving platform and the drive speed in the branch PPPS can be obtained.
3.3. Force transmission performance analysis
The calculation process for the motion/force transmission performance index [Reference Liping, Huayang, Liwen and Yu24, Reference Wang, Wu and Liu25] of the 3RRS/PPPS PM can be summarized as follows:
(1) Analysis of constraint wrench and transmission force screw
From the fixed coordinate system established by the PM, the constraint wrench of the mechanism is determined as follows:
 \begin{equation} \boldsymbol{S}_{C}=\left\{\begin{array}{l} \boldsymbol{$}_{1}^{r}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} -\frac{\sqrt{3}/6}{6}R & -\frac{R}{2} & 0 & ; & {}^{O}\boldsymbol{A}{_{1}^{}}\times \boldsymbol{S}_{1} \end{array}\right)\\[5pt] \boldsymbol{$}_{2}^{r}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} -\frac{\sqrt{3}}{6}R & \frac{R}{2} & 0 & ; & {}^{O}\boldsymbol{A}{_{2}^{}}\times \boldsymbol{S}_{2} \end{array}\right)\\[5pt] \boldsymbol{$}_{3}^{r}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 1 & 0 & 0 & ; & {}^{O}\boldsymbol{A}{_{3}^{}}\times \boldsymbol{S}_{3} \end{array}\right) \end{array}\right. \end{equation}
where
S
1,
S
2, and
S
3 represent the direction vectors of the constraint wrench
 $\boldsymbol{$}_{1}^{r}, \boldsymbol{$}_{2}^{r}, \boldsymbol{$}_{3}^{r}$
, and the direction of the constraint wrench is parallel to the axis of the revolute joint.
Since the driving branch PPPS itself does not provide a constraint force on the moving platform, the constraint force screw
 $\boldsymbol{$}_{i}^{r}$
generated after locking the ith drive in the branch becomes the ith transmission force screw
 $\boldsymbol{$}_{Ti}$
, which can be solved similarly to the transmission force screw corresponding to the other two drives in the branch. The transmission force screw of the mechanism can be expressed as:
 \begin{equation} \boldsymbol{$}_{T}=\left\{\begin{array}{l} \boldsymbol{$}_{T1}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 1 & 0 & 0 & ; & 0 & h & 0 \end{array}\right)\\[5pt] \boldsymbol{$}_{T2}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 1 & 0 & ; & -h & 0 & 0 \end{array}\right)\\[5pt] \boldsymbol{$}_{T3}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 0 & 1 & ; & 0 & 0 & 0 \end{array}\right) \end{array}\right. \end{equation}
Each force transmitting screw passes through the center A
4 point of the spherical joint and is parallel to its corresponding moving direction, that is,
 $\boldsymbol{$}_{T1}$
parallel to FH,
 $\boldsymbol{$}_{T2}$
parallel to EF, and
 $\boldsymbol{$}_{T3}$
parallel to HA
4.
(2) Input and output motion wrench analysis
The PPPS branch is a drive branch, and the three prismatic joints in the branch are drives. Therefore, the input motion wrench (ITS) is:
 \begin{equation} \boldsymbol{$}_{I}=\left\{\begin{array}{l} \boldsymbol{$}_{I1}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 0 & 0 & 1 & 0 & 0 \end{array}\right)\\[5pt] \boldsymbol{$}_{I2}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 0 & 0 & 0 & 1 & 0 \end{array}\right)\\[5pt] \boldsymbol{$}_{I3}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} 0 & 0 & 0 & 0 & 0 & 1 \end{array}\right) \end{array}\right. \end{equation}
When solving the output motion screw corresponding to the FH drive joint in the PPPS branch, lock all drive joints except the FH drive joint and add two constraint wrenches
 $\boldsymbol{$}_{T2}, \boldsymbol{$}_{T3}$
to the constraint wrench system of the branch moving platform based on Eq. (26). At this time, the mechanism is a single DOF mechanism. To solve the inverse screw of the constrained wrench system
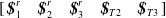 $[\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} \boldsymbol{$}_{1}^{r} & \boldsymbol{$}_{2}^{r} & \boldsymbol{$}_{3}^{r} & \boldsymbol{$}_{T2} & \boldsymbol{$}_{T3} \end{array}]$
, the instantaneous motion wrench of the moving platform, namely the output motion wrench
 $\boldsymbol{$}_{O1}$
corresponding to the FH drive joint, can be obtained from the following equation set as shown in the following equation:
 \begin{equation} \left\{\begin{array}{l} \boldsymbol{$}_{O1}\circ \boldsymbol{$}_{1}^{r}=0\\[3pt] \boldsymbol{$}_{O1}\circ \boldsymbol{$}_{2}^{r}=0\\[3pt] \boldsymbol{$}_{O1}\circ \boldsymbol{$}_{3}^{r}=0\\[3pt] \boldsymbol{$}_{O1}\circ \boldsymbol{$}_{T2}=0\\[3pt] \boldsymbol{$}_{O1}\circ \boldsymbol{$}_{T3}=0\\[3pt] \boldsymbol{$}_{O1}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} L_{1} & M_{1} & N_{1} & ; & P_{1} & Q_{1} & R_{1} \end{array}\right)\\[3pt] {L_{1}}^{2}+{M_{1}}^{2}+{N_{1}}^{2}=1 \end{array}\right. \end{equation}
Similarly, the output motion wrenches of the EF and HA 4 prismatic joints are:
 \begin{equation} \begin{array}{l} \boldsymbol{$}_{O2}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} L_{2} & M_{2} & N_{2} & ; & P_{2} & Q_{2} & R_{2} \end{array}\right)\\[3pt] \boldsymbol{$}_{O3}=\left(\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} L_{3} & M_{3} & N_{3} & ; & P_{3} & Q_{3} & R_{3} \end{array}\right) \end{array} \end{equation}
(3) Input and output transmission performance analysis
The input transmission performance index reflects the transmission performance of energy from the input (drive) to the branch, and its expression is given by:
 \begin{equation} \lambda _{i}=\frac{\left| \boldsymbol{$}_{Ti}\circ \boldsymbol{$}_{Ii}\right| }{\left| \boldsymbol{$}_{Ti}\circ \boldsymbol{$}_{Ii}\right| _{\max }} \end{equation}
Taking equations (25) and (26) into Eq. (28), it is calculated according to the maximum transmission power model.
 $\lambda _{1}, \lambda _{2}, \lambda _{3}$
are always 1.
From a mechanistic standpoint, the input transmission performance index of the branch is determined by the cosine of the angle between the transmission force and the velocity direction of the input prismatic joints. Given that all driving joints in the PPPS branch are prismatic joints, the direction of the transmission force for each driving joint is always parallel to the input motion direction of the joint. Therefore, the cosine of the included angle is 1, which is always the best angle for power transmission (as shown in Figure 10, the colors in the Figure indicate the minimum input transmission performance of the PM in different postures). It has better input transmission performance during mechanism movement.
Input transmission performance of the 3RRS/PPPS PM.

The output transmission performance index reflects force transmission efficiency from the branch to the output end (moving platform). It is expressed as follows:
 \begin{equation} \eta _{i}=\frac{\left| \boldsymbol{$}_{Ti}\circ \boldsymbol{$}_{Oi}\right| }{\left| \boldsymbol{$}_{Ti}\circ \boldsymbol{$}_{Oi}\right| _{\max }}=\frac{\left| \left(h_{Ti}+h_{Oi}\right)\cos \theta -d\sin \theta \right| }{\sqrt{\left(h_{Ti}+h_{Oi}\right)^{2}+{d_{\max }}^{2}}} \end{equation}
where
 $h_{Ti}$
is the pitch of the force transmitting screw,
 $h_{Ti}=0;h_{Oi}$
is the pitch of the output motion wrench,
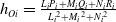 $h_{Oi}=\frac{L_{i}P_{i}+M_{i}Q_{i}+N_{i}R_{i}}{{L_{i}}^{2}+{M_{i}}^{2}+{N_{i}}^{2}}$
; d is the common perpendicular distance between the output motion wrench and the transmission force wrench; d
max is the theoretical maximum distance between the output motion wrench and the transmission force wrench;
 $\theta$
is the included angle between the output motion wrench and the transmission force wrench.
Taking Eq. (25), Eq. (26), and Eq. (27) into Eq. (29), it is found that,
 $\eta _{1}, \eta _{2}$
, and
 $\eta _{3}$
are always 1(as shown in Figure 11, the colors in the Figure indicate the minimum output transmission performance of the PM in different postures), which has good output transmission performance in mechanism motion.
Output transmission performance of the 3RRS/PPPS PM.

Using the aforementioned method, the minimum input and output transmission performance of the 3RRS PM in the workspace is obtained (as shown in Figure 12 and Figure 13, the colors in the Figure indicate the minimum transmission performance of the PM in different postures). Based on the calculation results, it is concluded that the 3RRS/PPPS mechanism has better motion and force transmission performance, along with higher power transmission performance, in comparison to the 3RRS PM transmission.
Input transmission performance of the 3RRS PM.

Output transmission performance of the 3RRS PM.

3.4. 4-3RRS/PPPS motion verification
Establish the Figure 8(b) model in Adams and validate it using MATLAB and Adams. The displacements of the three drivers can be expressed as:
 \begin{equation} \left\{\begin{array}{l} \dot{P}1=10\times t\\[5pt] \dot{P}2=5\times t\\[5pt] \dot{P}3=2\times t \end{array}\right. \end{equation}
where t represents time.
The end pose
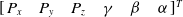 $[\begin{array}{l@{\quad}l@{\quad}l@{\quad}l@{\quad}l@{\quad}l} P_{x} & P_{y} & P_{z} & \gamma & \beta & \alpha \end{array}]^{T}$
of each 3RRS/PPPS PM platform can be obtained. Figure 14 shows the end pose of each 3RRS/PPPS PM platform, and the motion of the four PMs is the same. In Figure 14,
 represents Matlab values for four output platforms.
 represents Adams values for four output platforms.
4-3RRS/PPPS PM moving platform posture.

It has been verified that centralized management of drives can enable multiple PMs to perform the same motion with fewer drives.
4. Conclusion
This paper proposes a new PM type with a separate drive and constraint. An active drive branch is added to the original PMs, consolidating all drives into this branch. It is essential to ensure that the constraint wrenches of the original PM and the driving force wrenches are linearly independent. Consequently, a new PM of 3T, 3R, 2T1R, and 2R1T is synthesized.
Taking the commonly used 3-DOF 2R1T parallel mechanism 3RRS-PPPPS as an example, the accompanying motion of the mechanism was analyzed. The closed-loop vector method is employed to solve for the lengths of actuated branches. The mapping relationship between the input and output velocities of the mechanism is analyzed using the method of the complete Jacobi matrix.
The input and output motion screws are used to analyze the input and output transmission performance, and the input and output transmission efficiency of the mechanism is obtained to be constant at 1. The input and output transmission performances are analyzed using the input and output motion screws. The input and output transmission performance index of the mechanism is always 1. Matlab and Adams are used to verify the correctness of the array’s output with fewer inputs.
In short, the drivers and constraints of the PM are separated, and the drive can be more easily centrally managed and maintained. Thus, the new PM with fewer inputs and more outputs is proposed, with a wide range of application scenarios in antennas, entertainment facilities, and other occasions. But if the drive is concentrated on a branch and is far from the end, it will generate a certain amount of torque on the drive. However, no corresponding prototype has been made for this work, so the experiment has not been conducted. The prototype and complete experimental verification will be made in our future work.
Author contributions
Yundou Xu and Yongsheng Zhao conceived and designed the study. Jiabin Wu performed statistical analyses. Yu Wang, Can Qiu, and Xiaoyu He wrote the article.
Funding Support
Supported by the National Natural Science Foundation of China (Grant No. 52375029)
Competing interests
The authors declare no competing financial interests.
Ethical standards
None.



