Nomenclature
- EKF
-
Extended Kalman Filter
- UKF
-
Unscented Kalman Filter
- CKF
-
Cubature Kalman Filter
- EnKF
-
Ensemble Kalman Filter
- MDKF
-
Measurement Differencing Kalman Filter
- RAKF
-
Robust Adaptive Kalman Filter
- AF-BUKF
-
Adaptive Fading Bayesian Unscented Kalman Filter
- KF
-
Kalman Filter
- SVD
-
Singular Value Decomposition
- MSE
-
Mean Squared Error
- INS
-
Inertial Navigation Systems
- UAS
-
Unmanned Aircraft Systems
- UAV
-
Unmanned Aerial Vehicle
-
 $V$
-
True airspeed
-
$q$
-
Pitch rate; also dynamic pressure (
$q = 0.5 \rho {V^{2}}$
) -
${\delta _e}$
-
Elevator deflection
-
${F_e}$
-
Thrust
-
$m$
-
Mass
-
$S$
-
Wing area
-
$c$
-
Wing chord
-
${I_y}$
-
Moment of inertia about the pitch axis
-
${I_{tx}}$
-
Engine location relative to the center of gravity (x-component)
-
${I_{tz}}$
-
Engine location relative to the center of gravity (z-component)
-
$n$
-
Dimension of the state vector
-
$a$
-
Tuning parameter in UKF
-
${x_k}$
-
State vector at time
$k$
-
${\hat x_k}$
-
Estimated state vector at time
$k$
-
${P_k}$
-
Covariance matrix at time
$k$
-
${S_k}$
-
Cholesky decomposition of the covariance matrix (
${P_k} = {S_k}S_k^T$
) -
$\chi _k^i$
-
Cubature points or sigma points
-
$Q$
-
Process noise covariance matrix
-
$R$
-
Measurement noise covariance matrix
-
$P_{k + 1}^ - $
-
Predicted state covariance
-
${K_{k + 1}}$
-
Kalman gain
-
${z_k}$
-
Measurement vector at time
$k$
-
${\hat z_k}$
-
Predicted measurement mean
-
${P_{zz}}$
-
Measurement covariance
-
${P_{xz}}$
-
Cross-covariance matrix
-
${w_k}$
-
Process noise
-
${v_k}$
-
Measurement noise
-
${N_e}$
-
Number of ensemble members (in EnKF)
-
${\eta^{\left( i \right)}}$
-
Initial perturbations in EnKF (
${\eta^{\left( i \right)}}\sim {\cal N}\left( {0,{P_0}} \right)$
) -
$C$
-
Output matrix
-
${X_{00}}$
-
Initial state vector
-
$f$
-
State transition function (nonlinear)
-
$h$
-
Measurement function (nonlinear)
-
$W_m^i$
-
Weights for mean in UKF
-
$W_c^i$
-
Weights for covariance in UKF
-
${C_D}$
-
Drag coefficient
-
${C_L}$
-
Lift coefficient
-
${C_m}$
-
Pitching moment coefficient


Greek Symbols
-
$\alpha $
-
Angle of attack
-
$\theta $
-
Pitch angle
-
$\psi $
-
Inclination angle of the engines
-
$\rho $
-
Air density
-
$\lambda $
-
Scaling parameter in UKF (
$ = {a^2}\left( {n + \kappa } \right) - n$
) -
$\kappa $
-
Tuning parameter in UKF


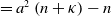

1.0 Introduction
Aircraft state estimation plays a crucial role in modern flight control systems, serving as the foundation for navigation, guidance and control algorithms. Accurate estimation of flight parameters, such as velocity, angle-of-attack and pitch rate, is essential for ensuring safe and efficient aircraft operations. However, the inherent nonlinearity of aircraft dynamics, coupled with various sources of uncertainty including sensor noise, atmospheric disturbances and modeling errors, makes this estimation task particularly challenging [Reference Chowdhary and Jategaonkar1–Reference Elenchezhiyan and Kumar4].
Traditional nonlinear estimation techniques, such as the EKF, have been widely used in aircraft applications. However, these methods can exhibit significant performance degradation when dealing with highly nonlinear systems or in the presence of large uncertainties. This limitation has motivated the development and application of more sophisticated nonlinear filtering techniques, each offering distinct advantages and trade-offs in terms of accuracy, computational efficiency and robustness [Reference Hajiyev and Soken5, Reference Beard, Leishman, Macdonald and McLain6].
Recent advances in Kalman-based estimation algorithms have significantly enhanced their applicability to aerospace systems, particularly in the context of nonlinear and high-dynamic environments. For instance, Zhang et al. [Reference Zhang, Wang, Gao and Wang7] conducted a comparative study involving several filters–including the unscented Kalman filter (UKF), cubature Kalman filter (CKF), square-root CKF (SRCKF) and SVD-based CKF (SVD-CKF)–for altitude estimation of high-spinning aircraft. By integrating these filters with an H
 $\infty $
framework, the study demonstrated improved robustness to system uncertainties. Notably, the SRCKF and SVD-CKF outperformed traditional methods in terms of numerical stability and estimation accuracy. These results highlight the value of square-root implementations in reducing computational errors and maintaining filter consistency under rapidly changing flight dynamics [Reference Julier and Uhlmann8–Reference Evensen10].
Similarly, Ref. (Reference Ahmed, Coelho and Bousson11) provided comprehensive studies of nonlinear state estimation techniques with Gaussian priors, focusing on their relevance to aerospace systems. The authors reviewed popular Kalman filtering variants, such as the EnKF, UKF, CKF, and extended Kalman filter (EKF), from an aircraft perspective. Their analysis underscores the trade-offs between computational complexity and estimation accuracy, with UKF and CKF emerging as preferred choices for handling nonlinearities in aircraft state estimation due to their balance of performance and efficiency [Reference Doucet, De Freitas and Gordon12].
Early work by Ref. (Reference Kappl13) laid foundational insights into nonlinear estimation via Kalman filtering for missile systems. This study utilised noisy measurements of body angular rate, normal acceleration, and control surface deflection to estimate critical states such as air density, missile velocity, and angle-of-attack. The findings emphasised the estimator’s potential integration into adaptive control schemes, illustrating the enduring relevance of Kalman-based methods in adaptive aerospace applications.
More recent advancements address specific challenges, such as errors in INS [Reference Hajiyev14]. Proposed the multi-dimensional Kalman filter (MDKF) to compensate for time-correlated INS measurement errors in a multi-input/output aircraft model. Comparing MDKF with conventional KF and robust adaptive Kalman filter (RAKF), the study demonstrated MDKF’s superior resilience to noise-increment-type INS errors, making it a promising solution for robust aircraft state estimation.
In the context of unmanned aircraft systems (UAS) [Reference Liu and Chan15], explored the Adaptive Fading Bayesian AF-BUKF for state estimation. Their experimental results, validated on simulated and real UAS data, showed that AF-BUKF outperforms traditional methods by adapting to changing system dynamics, enhancing estimation accuracy for UAS navigation and control. This adaptability is particularly valuable in unpredictable operational environments.
Finally, Ref. (Reference Afshari, Gadsden and Habibi16) provided a general review of Gaussian filters for state and parameter estimation in stochastic dynamic systems, with applications extending to aerospace systems. The authors categorised filters into linear optimal, nonlinear, adaptive and robust filtering groups, emphasising the Bayesian framework and Gaussian noise assumptions. Their work offers a theoretical foundation for understanding the evolution of Kalman-based techniques and their practical implementation in real-time control systems.
Among these advanced techniques, three approaches have gained particular attention in the aerospace community: the UKF, which uses sigma points to propagate the state distribution; the CKF, which employs spherical-radial cubature rules for numerical integration; and the EnKF, which utilises a Monte Carlo approach with randomly generated ensemble members. Although these methods have been individually studied in various applications, a comprehensive comparative analysis of their robustness in estimating the state of aircrafts remains limited according to the authors’ knowledge [Reference Dwivedi, Bhale, Bhattacharya and Padhi17–Reference Arasaratnam and Haykin20].
This paper addresses this gap by presenting a systematic evaluation of these three nonlinear filtering techniques in the context of aircraft state estimation. Our analysis focuses particularly on their performance under challenging conditions that are commonly encountered in real-world applications, including sensor noise, model uncertainties, and initial state errors. By examining their performance across different flight parameters and operating conditions, a comprehensive analysis was carried out to choose a filter for aircraft state estimation.
The structure of the paper is as follows: Section 2 presents the nonlinear state estimation framework, outlining the discrete-time system formulation and the longitudinal aircraft dynamics model employed in this work. Section 3 presents the methodology, detailing the implementation of the CKF, UKF and EnKF. Section 4 provides a comprehensive analysis of the filters’ performance under varying levels of initial condition and plant-model mismatch, supported by simulation results and quantitative metrics. Finally, the conclusions section summarises the key findings and discusses potential directions for future research in robust nonlinear filtering for aerospace applications.
2.0 Problem formation
Reliable real-time state estimation is fundamental to modern flight control, navigation and guidance systems. Fixed-wing aircraft exhibit inherently nonlinear dynamics, especially during manoeuvres such as climbs, descents, coordinated turns and stall recoveries. These nonlinearities stem from aerodynamic forces and moments, actuator characteristics and sensor imperfections. Moreover, several critical states such as true airspeed, attitude angles and wind components, are not directly measurable, necessitating the use of robust estimation frameworks. Classical linear techniques often prove inadequate in the presence of nonlinearities and uncertainties. This study formulates a nonlinear estimation problem tailored for implementation in flight control systems and evaluates advanced filtering methods to address these challenges.
The evolution of a nonlinear system in discrete time can be represented by the following equations:
 \begin{align}{x_{k + 1}} = f\left( {{x_k},{u_k}} \right) + {w_k}, \end{align}
 \begin{align}{y_k} = h\left( {{x_k},{u_k}} \right) + {v_k}. \\[5pt] \nonumber \end{align}
Here,
 ${x_k} \in {{\mathbb R}^n}$
is the state vector at the
 ${k^{{\mathrm{th}}}}$
time step,
 ${u_k} \in {{\mathbb R}^m}$
is the control input vector and
 ${y_k} \in {{\mathbb R}^p}$
denotes the measurement vector derived from onboard sensors. The terms
 ${w_k}$
and
 ${v_k}$
represent the process and measurement noise, respectively, both modeled as zero-mean Gaussian white noise with covariance matrices
 $Q$
and
 $R$
.
The goal is to estimate the full state vector
 ${x_k}$
at each time step using the history of measurements
 $\left\{ {{y_1},{y_2}, \ldots ,{y_k}} \right\}$
and known input
 $\left\{ {{u_1},{u_2}, \ldots ,{u_k}} \right\}$
. Recursive nonlinear filtering techniques such as the EKF, UKF and CKF are employed to estimate the unmeasured states from the available sensor data.
2.1 Longitudinal aircraft dynamics
The foundation of accurate estimation lies in a reliable dynamic model. The equations of motion describe the aircraft dynamics by incorporating the forces and moments acting upon the vehicle. In general, the longitudinal and lateral-directional modes of motion are coupled. However, under assumptions of small perturbations, low angles of attack and moderate angular rates, this coupling can be considered negligible. As a result, it is often convenient to analyse longitudinal dynamics separately [Reference Kumar and Ghosh21, Reference Jategaonkar22].
In this study, the longitudinal motion of the aircraft is modeled using the following set of nonlinear differential equations:
 \begin{align} \begin{array}{*{20}{l}}{\dot V} {}{\displaystyle = \frac{{qS}}{m}{C_D} + g{\mathrm{sin}}\left( {\alpha - \theta } \right) + \frac{{{F_e}}}{m}{\mathrm{cos}}\left( {\alpha + \psi } \right),} \\[4pt] {\dot \alpha } {}{\displaystyle = \frac{{qS}}{{mV}}{C_L} + q + \frac{g}{V}{\mathrm{cos}}\left( {\alpha - \theta } \right) + \frac{{{F_e}}}{{mV}}{\mathrm{sin}}\left( {\alpha + \psi } \right),}\\[4pt] {\dot \theta } {}{ = q,}\\[4pt] {\dot q} {}{\displaystyle = \frac{{qS}}{{{I_y}}}{C_m} + \frac{{{F_e}}}{{{I_y}}}{\mathrm{cos}}\left( {{l_{tx}}{\mathrm{sin}}\psi + {l_{tz}}{\mathrm{cos}}\psi } \right),} \end{array} \end{align}
The state variables in Equation (3) are defined as follows:
 $V$
is the true airspeed,
 $\alpha $
is the angle-of-attack,
 $\theta $
is the pitch angle and
 $q$
is the pitch rate. The control inputs include elevator deflection
 ${\delta _e}$
, thrust force
 ${F_e}$
and engine inclination angle
 $\psi $
. The dynamic pressure is given by
 $q = 0.5\rho {V^2}$
, where
 $\rho $
is the air density. Additional aircraft parameters include the mass
 $m$
, wing area
 $S$
, mean aerodynamic chord
 $c$
, moment of inertia about the pitch axis
 ${I_y}$
and the engine locations relative to the centre of gravity, denoted by
 ${l_{tx}}$
and
 ${l_{tz}}$
. The aerodynamic force and moment coefficients incorporated into the equations of motion are the drag coefficient
 ${C_D}$
, representing aerodynamic resistance; the lift coefficient
 ${C_L}$
, representing the aerodynamic force perpendicular to the flight direction; and the pitching moment coefficient
 ${C_m}$
, representing the aerodynamic moment about the lateral axis. The aircraft model is described as:
State vector:
 $ = {[V,\alpha ,\theta ,q]^{\rm T}}$
; Input vector:
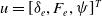 $u = {[{\delta _e},{F_e},\psi ]^{\rm T}}$
; Measurement vector:
 $y = \left[ \theta \right]$
Only the pitch angle (
 $\theta $
) is assumed to be directly measured by the onboard sensors, and the remaining states are estimated through the filters. The measurement process assumes ideal sensors with additive zero-mean Gaussian white noise, as characterised by the covariance matrix
 $R$
. Similarly, process noise is modeled as zero-mean Gaussian noise with covariance
 $Q$
, consistent with standard stochastic formulations. Simulation and filtering processes assume a sampling rate of 50 Hz.
3.0 Methodology
This section presents the nonlinear state estimation techniques employed in this study: the CKF, the UKF and the EnKF. These filters offer enhanced performance in nonlinear dynamic systems by approximating state distributions using distinct approaches such as cubature rules, unscented transforms and ensemble sampling.
3.1 Cubature Kalman Filter (CKF)
The CKF extends the standard Kalman filter framework to handle systems with nonlinear dynamics more effectively. It utilises the third-degree spherical-radial cubature rule to accurately and efficiently compute the transformation of mean and covariance through nonlinear functions. In contrast to the EKF, which approximates nonlinearities through linearisation, the CKF employs a set of deterministic cubature points to represent the state distribution [Reference Arasaratnam and Haykin20].
3.1.1 Cubature points generation
Cubature points are derived using:
 \begin{align} \chi _k^i &= {{\boldsymbol{\boldsymbol{x}}}_k} + \sqrt n {\left( {{{\boldsymbol{\boldsymbol{S}}}_k}} \right)_i},{\mathrm{\;\;\;\;}}i = 1, \ldots ,n, \\[-10pt] \nonumber \end{align}
 \begin{align} \chi _k^{i + n} &= {{\boldsymbol{\boldsymbol{x}}}_k} - \sqrt n {\left( {{{\boldsymbol{\boldsymbol{S}}}_k}} \right)_i},{\mathrm{\;\;\;\;}}i = 1, \ldots ,n, \\[6pt] \nonumber \end{align}
where:
-
•
$n$
is the dimension of the state vector, -
•
${{\boldsymbol{S}}_k}$
is the Cholesky decomposition of the covariance matrix
${{\boldsymbol{P}}_k}$
:
${{\boldsymbol{P}}_k} = {{\boldsymbol{S}}_k}{\boldsymbol{S}}_k^T$
.


3.1.2 Prediction step
Each cubature point is propagated through the system dynamics:
 \begin{align} \chi _{k + 1}^i = f\left( {\chi _k^i,{u_k}} \right) + {w_k}, \end{align}
The predicted state and covariance are:
 \begin{align} {{{\hat {\boldsymbol{x}}}}_{k + 1}} &= \frac{1}{{2n}}\mathop \sum \limits_{i = 1}^{2n} \chi _{k + 1}^i, \end{align}
 \begin{align} {\boldsymbol{P}}_{k + 1}^ - &= \frac{1}{{2n}}\mathop \sum \limits_{i = 1}^{2n} \left( {\chi _{k + 1}^i - {{{\hat{\boldsymbol{x}}}}_{k + 1}}} \right){(\chi _{k + 1}^i - {{\hat{\boldsymbol{x}}}_{k + 1}})^T} + {\boldsymbol{Q}}.\end{align}
3.1.3 Measurement update
Measurement propagation and update are performed as:
 \begin{align} \gamma _{k + 1}^i &= h\left( {\chi _{k + 1}^i} \right) + {v_k}, \end{align}
 \begin{align} {{\hat{\boldsymbol{z}}}_{k + 1}} &= \frac{1}{{2n}}\mathop \sum \limits_{i = 1}^{2n} \gamma _{k + 1}^i, \end{align}
 \begin{align} {{\boldsymbol{P}}_{{z_{k + 1}}}} &= \frac{1}{{2n}}\mathop \sum \limits_{i = 1}^{2n} \left( {\gamma _{k + 1}^i - {{{\hat{\boldsymbol{z}}}}_{k + 1}}} \right){(\gamma _{k + 1}^i - {{\hat{\boldsymbol{z}}}_{k + 1}})^T} + {\boldsymbol{R}}, \end{align}
 \begin{align} {{\boldsymbol{P}}_{xz}} &= \frac{1}{{2n}}\mathop \sum \limits_{i = 1}^{2n} \left( {\chi _{k + 1}^i - {{{\hat{\boldsymbol{x}}}}_{k + 1}}} \right){(\gamma _{k + 1}^i - {{\hat{\boldsymbol{z}}}_{k + 1}})^T}, \\[2pt] \nonumber \end{align}
3.1.4 Kalman gain and state update
The Kalman gain and state update equations are:
 \begin{align} {{\boldsymbol{K}}_{k + 1}} &= {{\boldsymbol{P}}_{xz}}{\boldsymbol{P}}_{{z_{k + 1}}}^{ - 1}, \\[-10pt] \nonumber \end{align}
 \begin{align} {{\boldsymbol{x}}_{k + 1}} &= {{\hat{\boldsymbol{x}}}_{k + 1}} + {{\boldsymbol{K}}_{ + 1}}\left( {{{\boldsymbol{z}}_{k + 1}} - {{{\hat{\boldsymbol{z}}}}_{k + 1}}} \right), \\[-10pt] \nonumber \end{align}
 \begin{align} {{\boldsymbol{P}}_{k + 1}} &= {\boldsymbol{P}}_{k + 1}^ - - {{\boldsymbol{K}}_{k + 1}}{{\boldsymbol{P}}_{{z_{k + 1}}}}{\boldsymbol{K}}_{k + 1}^T. \\[2pt] \nonumber \end{align}
3.2 Unscented Kalman filter (UKF)
The UKF overcomes the drawbacks of the extended Kalman filter by eliminating the need for linearisation. It utilises the uscented transform, which propagates a carefully chosen set of sigma points through the nonlinear system to more precisely capture the mean and covariance of the state distribution [Reference Simon23, Reference Crassidis and Junkins24].
3.2.1 Sigma point generation
 \begin{align} \chi _k^0 &= {{\boldsymbol{x}}_k}, \end{align}
 \begin{align} \chi _k^i &= {{\boldsymbol{x}}_k} + {\left( {\sqrt {\left( {n + \lambda } \right){{\boldsymbol{P}}_k}} } \right)_i},{\mathrm{\;\;\;\;}}i = 1, \ldots, n, \end{align}
 \begin{align} \chi _k^i &= {{\boldsymbol{x}}_k} - {\left( {\sqrt {\left( {n + \lambda } \right){{\boldsymbol{P}}_k}} } \right)_{i - n}},{\mathrm{\;\;\;\;}}i = n + 1, \ldots ,2n,\\[6pt] \nonumber \end{align}
where
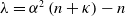 $\lambda = {\alpha ^2}\left( {n + \kappa } \right) - n $
.
3.2.2 Prediction step
 \begin{align} \chi _{k + 1}^i &= f\left( {\chi _k^i,{u_k}} \right) + {w_k}, \end{align}
 \begin{align} {{\hat{\boldsymbol{x}}}_{k + 1}} &= \mathop \sum \limits_{i = 0}^{2n} W_m^i\chi _{k + 1}^i, \end{align}
 \begin{align} {\boldsymbol{P}}_{k + 1}^ - &= \mathop \sum \limits_{i = 0}^{2n} W_c^i\left( {\chi _{k + 1}^i - {{{\hat{\boldsymbol{x}}}}_{k + 1}}} \right){(\chi _{k + 1}^i - {{\hat{\boldsymbol{x}}}_{k + 1}})^T} + {\boldsymbol{Q}}. \\[2pt] \nonumber \end{align}
3.2.3 Measurement update
 \begin{align} \gamma _{k + 1}^i &= h\left( {\chi _{k + 1}^i} \right) + {v_k}, \end{align}
 \begin{align} {{\hat{\boldsymbol{z}}}_{k + 1}} &= \mathop \sum \limits_{i = 0}^{2n} W_m^i\gamma _{k + 1}^i, \end{align}
 \begin{align} {{\boldsymbol{P}}_{{z_{k + 1}}}} &= \mathop \sum \limits_{i = 0}^2 W_c^i\left( {\gamma _{k + 1}^i - {{{\hat{\boldsymbol{z}}}}_{k + 1}}} \right){(\gamma _{k + 1}^i - {{\hat{\boldsymbol{z}}}_{k + 1}})^T} + {\boldsymbol{R}}, \end{align}
 \begin{align} {{\boldsymbol{P}}_{xz}} &= \mathop \sum \limits_{i = 0}^{2n} W_c^i\left( {\chi _{k + 1}^i - {{{\hat{\boldsymbol{x}}}}_{k + 1}}} \right){(\gamma _{k + 1}^i - {{\hat{\boldsymbol{z}}}_{k + 1}})^T}. \end{align}
3.2.4 Kalman gain and state update
 \begin{align} {{\boldsymbol{K}}_{k + 1}} &= {{\boldsymbol{P}}_{xz}}{\boldsymbol{P}}_{{z_{k + 1}}}^{ - 1}, \end{align}
 \begin{align} {{\boldsymbol{x}}_{k + 1}} &= {{\hat{\boldsymbol{x}}}_{k + 1}} + {{\boldsymbol{K}}_{ + 1}}\left( {{{\boldsymbol{z}}_{k + 1}} - {{{\hat{\boldsymbol{z}}}}_{k + 1}}} \right), \\[-10pt] \nonumber \end{align}
 \begin{align} {{\boldsymbol{P}}_{k + 1}} &= {\boldsymbol{P}}_{k + 1}^ - - {{\boldsymbol{K}}_{k + 1}}{{\boldsymbol{P}}_{{z_{k + 1}}}}{\boldsymbol{K}}_{k + 1}^T. \\[2pt] \nonumber \end{align}
3.3 Ensemble Kalman filter (EnKF)
The EnKF is a Monte Carlo-based approach that is well-suited for high-dimensional, nonlinear systems. It approximates the mean and covariance of the state distribution using a collection of ensemble members, thereby eliminating the need for Jacobian matrices or analytical covariance propagation [Reference Simon23, Reference Chui and Chen25].
3.3.1 Initialisation
 \begin{align} {\boldsymbol{x}}_k^{\left( i \right)} = {{\boldsymbol{x}}_0} + {\eta ^{\left( i \right)}},{\mathrm{\;\;\;\;}}{\eta ^{\left( i \right)}}\sim {\mathcal N}\left( {0,{{\boldsymbol{P}}_0}} \right),{\mathrm{\;\;\;\;}}i = 1, \ldots ,{N_e}, \end{align}
3.3.2 Prediction step
 \begin{align} {\boldsymbol{x}}_{k + 1}^{\left( i \right)} &= f\left( {{\boldsymbol{x}}_k^{\left( i \right)},{u_k}} \right) + w_k^{\left( i \right)}, \end{align}
 \begin{align} {{\bar{\boldsymbol{x}}}_{k + 1}} &= \frac{1}{{{N_e}}}\mathop \sum \limits_{i = 1}^{{N_e}} {\boldsymbol{x}}_{k + 1}^{\left( i \right)}, \end{align}
 \begin{align} {\boldsymbol{P}}_{k + 1}^ - &= \frac{1}{{{N_e} - 1}}\mathop \sum \limits_{i = 1}^{{N_e}} \left( {{\boldsymbol{x}}_{k + 1}^{\left( i \right)} - {{{\bar{\boldsymbol{x}}}}_{k + 1}}} \right){({\boldsymbol{x}}_{k + 1}^{\left( i \right)} - {{\bar{\boldsymbol{x}}}_{k + 1}})^T}. \\[1pt] \nonumber \end{align}
3.3.3 Update step
 \begin{align} {\boldsymbol{z}}_{k + 1}^{\left( i \right)} &= h\left( {{\boldsymbol{x}}_{k + 1}^{\left( i \right)}} \right), \end{align}
 \begin{align} {{\bar{\boldsymbol{z}}}_{k + 1}} &= \frac{1}{{{N_e}}}\mathop \sum \limits_{i = 1}^{{N_e}} {\boldsymbol{z}}_{k + 1}^{\left( i \right)}, \end{align}
 \begin{align} {{\boldsymbol{P}}_{zz}} &= \frac{1}{{{N_e} - 1}}\mathop \sum \limits_{i = 1}^{{N_e}} \left( {{\boldsymbol{z}}_{k + 1}^{\left( i \right)} - {{{\bar{\boldsymbol{z}}}}_{k + 1}}} \right){({\boldsymbol{z}}_{k + 1}^{\left( i \right)} - {{\bar{\boldsymbol{z}}}_{k + 1}})^T} + {\boldsymbol{R}}, \end{align}
 \begin{align} {{\boldsymbol{P}}_{xz}} &= \frac{1}{{{N_e} - 1}}\mathop \sum \limits_{i = 1}^{{N_e}} \left( {{\boldsymbol{x}}_{k + 1}^{\left( i \right)} - {{{\bar{\boldsymbol{x}}}}_{k + 1}}} \right){({\boldsymbol{z}}_{k + 1}^{\left( i \right)} - {{\bar{\boldsymbol{z}}}_{k + 1}})^T}, \end{align}
3.3.4 Kalman gain and state update
 \begin{align} {{\boldsymbol{K}}_{k + 1}} &= {{\boldsymbol{P}}_{xz}}{\boldsymbol{P}}_{zz}^{ - 1}, \end{align}
 \begin{align} {\boldsymbol{x}}_{k + 1}^{\left( i \right)} &= {\boldsymbol{x}}_{k + 1}^{\left( i \right)} + {{\boldsymbol{K}}_{k + 1}}\left( {{{\boldsymbol{z}}_{k + 1}} - {{{\bar{\boldsymbol{z}}}}_{k + 1}}} \right), \end{align}
 \begin{align} {{\bar{\boldsymbol{x}}}_{k + 1}} &= \frac{1}{{{N_e}}}\mathop \sum \limits_{i = 1}^{{N_e}} {\boldsymbol{x}}_{k + 1}^{\left( i \right)}, \end{align}
 \begin{align} {{\boldsymbol{P}}_{k + 1}} &= \frac{1}{{{N_e} - 1}}\mathop \sum \limits_{i = 1}^{{N_e}} \left( {{\boldsymbol{x}}_{k + 1}^{\left( i \right)} - {{{\bar{\boldsymbol{x}}}}_{k + 1}}} \right){({\boldsymbol{x}}_{k + 1}^{\left( i \right)} - {{\bar{\boldsymbol{x}}}_{k + 1}})^T}. \\[2pt] \nonumber \end{align}
4.0 Results and discussion
To evaluate the robustness of the nonlinear filters, simulations were conducted under progressively challenging scenarios, including increasing levels of initial condition mismatch and plant-model mismatch.
In this study, plant-model mismatch refers to discrepancies between the true aircraft dynamics (used to generate synthetic measurement data) and the model assumed by the filters for state estimation. This mismatch is introduced by modifying the aerodynamic coefficients (
 ${C_D} $
), (
 ${C_L}$
) and (
 ${C_m}$
) in the simulation model, while retaining their nominal values in the estimator model. This mimics practical scenarios where the estimator is based on an approximate or outdated model of the aircraft, which may differ from actual behaviour due to model simplifications, structural modifications, or environmental effects.
Magnitude of mismatch
The plant-model mismatch was introduced in a staged manner as follows:
-
• Case I: No mismatch (ideal conditions).
-
• Case II: 25% initial condition mismatch only.
-
• Case III: 75% initial condition mismatch only.
-
• Case IV: Combined 95% initial condition and plant-model mismatch. The aerodynamic coefficients in the simulation model were scaled by up to
$ \pm $
95% of their nominal values, while the estimator continued to use the nominal values.

This setup allows a systematic evaluation of the sensitivity and robustness of each filter (UKF, CKF and EnKF) under increasing levels of uncertainty. The estimation accuracy in each case is assessed using the mean squared error (MSE) metric for all key flight states.
The performance of different estimatorsfor each filter was evaluated under various conditions of initial condition and plant-model mismatch as follows:
Error covariance matrix (
 $P$
:
 \begin{align}P = \left[ {\begin{array}{*{20}{l}}{156.25} &\quad {}{1.56} \\[3pt] {6.25{\mathrm{e}} - 6} &\quad {}{6.25{\mathrm{e}} - 6}\end{array}} \right]. \end{align}
Process noise covariance matrix(
 $Q$
):
 \begin{align}Q = \left[ {\begin{array}{*{20}{l}}{9.0{\mathrm{e}} - 4} &\quad {1.6{\mathrm{e}} - 3} \\[3pt] {1{\mathrm{e}} - 4} &\quad {}{1{\mathrm{e}} - 4}\end{array}} \right]. \end{align}
Measurement noise covariance matrix (
 $R$
):
 \begin{align}R = 1{\mathrm{e}} - 4. \end{align}
Output matrix (
 $C$
):
 \begin{align}C = \left[ {\begin{array}{*{20}{l}}{0, 0, 1, 0}\end{array}} \right]. \end{align}
Initial state:
 \begin{align} {X_{0|0}} = \left[ {\begin{array}{*{20}{l}}{50}\\5\\{0.1}\\{0.001}\end{array}} \right]. \end{align}
The results, presented in Figs 1–4, highlight the impact of these mismatches on estimation accuracy in terms of MSE.
Performance comparison without initial condition mismatch.

With 25% initial condition mismatch.

4.1 Case I
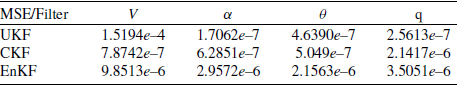
Performance without initial condition mismatch as shown in Table 1, the UKF consistently outperforms CKF and EnKF across all state variables (
 $V$
,
 $\alpha $
,
 $\theta $
and q), achieving the lowest MSE values. CKF performs moderately well as shown in Fig. 1, while EnKF exhibits the highest errors as illustrated in Fig. 2, indicating its sensitivity to measurement noise and sample variations.
Performance without initial condition mismatch and plant-model mismatch

With 75% initial condition mismatch.

With 95% initial condition and plant-model mismatch.

4.2 Case II
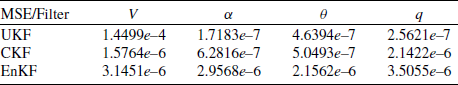
Effect of 25% initial condition mismatch with a 25% initial condition mismatch Table 2, the UKF maintains its robustness, showing only a slight increase in MSE compared to the ideal case. CKF also remains stable, while EnKF demonstrates a noticeable rise in error values, reinforcing its susceptibility to initial condition uncertainties.
Performance with 25% initial condition mismatch

4.3 Case III
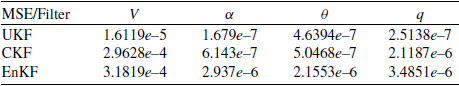
Effect of 75% initial condition mismatch Table 3 shows that increasing the initial condition mismatch to 75% significantly impacts CKF and EnKF, leading to higher MSE values, particularly in velocity (
 $V$
). The UKF remains the most stable, with minimal performance degradation as reflected from Fig. 3, indicating its superior adaptability to initial condition discrepancies.
Performance with 75% initial condition mismatch

4.4 Case IV: effect of 95
$ \% $
initial condition and plant-model mismatch

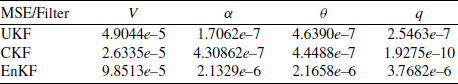
Under the most extreme mismatch scenario Table 4, the UKF continues to perform reliably, though its MSE increases compared to the lower mismatch cases. CKF experiences fluctuations in error values, whereas EnKF shows the highest degradation in performance shown in Fig. 4. The results confirm that UKF is the most resilient filter under large uncertainties, making it a preferred choice for UAV propulsion system state estimation.
Performance with 95% initial condition and plant-model mismatch

4.5 Discussion
-
• UKF consistently provides the lowest MSE, demonstrating its robustness across different mismatch scenarios.
-
• CKF shows moderate performance, with an increase in MSE under higher mismatches but still maintaining stability.
-
• EnKF is the most sensitive to mismatches, exhibiting significant performance degradation with increasing uncertainty.
The presented study underscores the importance of choosing the appropriate estimator based on system uncertainties, with UKF being the most reliable for accurate nonlinear aerodynamic predictions and generic modeling.
Stability considerations and algorithm suitability
In addition to estimation accuracy, the stability of filtering algorithms under uncertainty is a key factor in determining their suitability for real-world aerospace systems, particularly safety-critical applications. The unscented Kalman filter demonstrated the most stable behaviour across all mismatch scenarios. Its use of the unscented transform ensures consistent performance without requiring linearisation, which reduces the risk of divergence in highly nonlinear regimes. The UKF’s smooth convergence and robustness to large deviations make it particularly suitable for embedded flight systems where reliability is paramount.
The cubature Kalman filter also maintained stable estimates, although with slightly higher sensitivity to model mismatches compared to UKF. Its cubature-based approach provides good numerical stability, and the filter did not diverge in any of the cases considered. This makes CKF a viable choice when computational efficiency is important but where moderate uncertainty is expected.
The ensemble Kalman filter (EnKF) exhibited the highest variability and sensitivity, especially under severe mismatch conditions. Due to its reliance on stochastic sampling and ensemble spread, EnKF is more prone to instability if not properly tuned or if the ensemble size is insufficient. While EnKF performed reasonably well in estimating certain parameters like angle-of-attack, its convergence behaviour was less predictable, making it less suitable for real-time applications without adaptive mechanisms or stability-enhancing modifications.
From a stability standpoint, the UKF emerges as the most suitable for nonlinear state estimation in flight systems, followed by the CKF. The EnKF, although useful in specific contexts (e.g., large-scale systems or offline analysis), requires careful tuning and may need hybrid or adaptive enhancements for robust deployment in aerospace platforms.
5.0 Conclusions
This study carried out a detailed robustness analysis of three nonlinear filtering techniques–CKF, UKF and EnKF–for aircraft state estimation. The evaluation focused on estimating critical flight states such as velocity, angle-of-attack and pitch rate under scenarios involving sensor noise, modeling uncertainties and initial condition deviations. In this context, both process and measurement noise were actively included in the simulation, modeled as zero-mean Gaussian white noise with known variances.
The UKF demonstrated the highest estimation accuracy, especially for velocity and pitch rate, making it a strong candidate for applications demanding high precision. The EnKF showed notable robustness in estimating the angle-of-attack under severe uncertainty, indicating its utility in high-uncertainty environments. The CKF provided a balanced performance, offering a practical trade-off between accuracy and computational efficiency ideal for real-time implementations where resources are constrained.
These findings highlight the importance of filter selection in aerospace applications, particularly when robustness to uncertainty and computational feasibility are critical. Future research could investigate hybrid or adaptive filtering strategies to further enhance estimation accuracy and operational efficiency in real-world UAV systems.