


1. Introduction
Signature theory plays an important role in the field of reliability [Reference Da and Ding5, Reference Samaniego17] by describing various system structures with the help of concepts such as system signature [Reference Samaniego16], joint signature [Reference Navarro, Samaniego and Balakrishnan14, Reference Navarro, Samaniego and Balakrishnan15], dynamic signature [Reference Samaniego, Balakrishnan and Navarro18], minimal/maximal signature [Reference Navarro, Ruiz and Sandoval13], survival signature [Reference Coolen, Coolen-Maturi, Zamojski, Mazurkiewicz, Sugier, Walkowiak and Kacprzyk4], ordered signature [Reference Balakrishnan and Volterman2, Reference Yi, Balakrishnan and Li24], and their counterparts for multi-state coherent systems [Reference Yi, Balakrishnan and Cui21–Reference Yi, Balakrishnan and Li23, Reference Yi, Balakrishnan and Li25, Reference Yi, Balakrishnan and Li26, Reference Yi, Balakrishnan, Liu, Wang, Mi and Li28]. However, one of the main limitations of signature theory is that it assumes component lifetimes follow a continuous-time distribution, while many practical reliability systems actually have their component lifetimes to be discrete [Reference Baik and Cho1, Reference Dembinska and Eryilmaz6–Reference Hu, Hu, Wu and Yu11, Reference Shaked, Shanthikumar, Valdez-Torres and Özekici19].
For example, in communication network systems, the lifetimes of sensors are measured by numbers of communication cycles; in smart street light systems, the lifetimes of lights are measured by switching cycles or lighting days; in unmanned aerial vehicle systems, the lifetimes of aerial vehicles are measured by mission cycles; in hardware load balancer group systems, the lifetimes of hardware load balancers are measured by the amount of processed workload. There are many other similar systems in practice wherein the lifetimes are discrete.
To generalize signature theory from the continuous-time case to the discrete-time case, Balakrishnan et al. [Reference Balakrishnan, Yi and Goroncy3] first proposed a discrete-time signature based on the concept of signature in Samaniego [Reference Samaniego16], and they also discussed associated properties in detail, including reliability representation, stochastic ordering, and transformation formulae. Subsequently, Yi and Balakrishnan [Reference Yi and Balakrishnan20] generalized related results to two coherent systems with shared components by proposing a discrete-time joint signature based on the concept of joint signature originally due to Navarro et al. [Reference Navarro, Samaniego and Balakrishnan15].
In the present work, under the discrete-time assumption on component lifetimes, we further consider used coherent systems with a known number of failed components, and propose discrete-time dynamic signature and discrete-time residual signature for them, with detailed discussions on associated properties of residual systems. We also consider used coherent systems with shared components instead of single ones and propose discrete-time dynamic joint signature and discrete-time residual joint signature for them and then provide detailed discussions on associated properties. The main contributions of this paper are the development of discrete-time dynamic notion and residual signatures for used systems, and of their joint counterparts for two systems with shared components.
The rest of this paper proceeds as follows. In Section 2, we introduce the definitions of discrete-time dynamic signature and discrete-time residual signature for coherent systems with components whose lifetimes are independent and identically distributed (i.i.d.) from a discrete-time distribution, and associated properties are discussed in detail with some illustrative examples. In Section 3, related discussions in Section 2 are generalized to two coherent systems with shared components by a proposing discrete-time dynamic joint signature and a discrete-time residual joint signature. Some concluding remarks are finally made in Section 4.
2. Discrete-time dynamic signature
For coherent systems with i.i.d. discrete-time components, Balakrishnan et al. [Reference Balakrishnan, Yi and Goroncy3] generalized the definition of signature [Reference Samaniego16] in the continuous-time case as follows:
Definition 2.1. For a coherent system with  $n$ components and lifetime
 $T$, suppose the components have i.i.d. discrete lifetimes
 ${X_1}, \ldots ,{X_n}$ from a cumulative distribution function (cdf)
 $F(\cdot)$ and a probability mass function (pmf)
 $f(\cdot)$. Denoting the
 $i$th smallest component lifetime by
 ${X_{i:n}}$, the discrete-time signature of the system can be defined as
 \begin{equation*}{\boldsymbol{s}} = \left( {{s_{i}^{j_1,\ldots,j_{m}}},{{\rm ~}} j_1 +\cdots +j_m= n,{{\rm ~}}1\le i\le m\le n} \right),\end{equation*}
where
 \begin{equation*}{s_{i}^{j_1,\ldots,j_m}} = P( T = {X_{j_{(i-1)}+1 :n}}|{{E_{j_1,\ldots,j_m}}}) \end{equation*}
is the conditional probability that failure of the system is caused by the  $(j_{(i-1)}+1)$th component failure, given the event
 \begin{equation*}{E_{j_1,\ldots,j_m}}=\{X_{(1,\ldots,j_{(1)}):n} \lt {X_{(j_{(1)}+1,\ldots,j_{(2)}):n}} \lt \cdots \lt {X_{(j_{(m-1)} +1,\ldots,j_{(m)} ):n}}\},\end{equation*}
with  ${j_1},\ldots,{j_m}$ being the numbers of order statistics
 $X_{1:n},\ldots,X_{n:n}$ that are equal to the first, second,
 $\ldots$,
 $m$th distinct values, respectively. Here,
 ${X_{(u,\ldots,v):n}}$ is an abbreviation for
 ${X_{u:n}}=\cdots={X_{v:n}}$ (
 $1\le u \le v\le n$) and
 $j_{(i)}={j_1}+\cdots+{j_i}$ is the
 $i$th partial sum for
 $i=1,\ldots,m$. It is clear that
 $j_{(1)}=j_1$ and
 $j_{(m)}=\sum\nolimits_{i=1}^{m} {j_i} =n$. Without loss of generality, we set
 $j_{(0)}=0$ and
 $j_{(-1)} =-1$.
Remark 2.1. Define the event
 \begin{align*}
{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}=&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(k-1)}+1,\ldots,j_{(k)}):n}}\le t \lt \cr
&X_{(j_{(k)}+1,\ldots,j_{(k+1)}):n} \lt \cdots \lt {X_{(j_{(m-1)}+1,\ldots,j_{(m)}):n}}\},{{\rm ~}}t\ge k,
\end{align*}
and then for  $1\le k \le m-1$,
 $t\ge k$, we have
 \begin{align*}
&P(T \gt t|{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}})\cr
=& {\sum\limits_{i = 1}^{m} {P( T \gt t|T = {X_{j_{(i-1)}+1 :n}},{{\rm ~}}E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}) } } P( T = {X_{j_{(i-1)}+1 :n}}|{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}) \cr
=& {\sum\limits_{i = 1}^{m} {P( {X_{j_{(i-1)}+1 :n}} \gt t|T = {X_{j_{(i-1)}+1 :n}},{{\rm ~}}E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}) } } P( T = {X_{j_{(i-1)}+1 :n}}|{E_{j_1,\ldots,j_m}}) \cr
=& {\sum\limits_{i = 1}^{m} {P( {X_{j_{(i-1)}+1 :n}} \gt t|E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}) } } {s_{i}^{j_1,\ldots,j_m}}
= {\sum\limits_{i = k+1}^{m} {s_{i}^{j_1,\ldots,j_m}} } .
\end{align*}
Based on Remark 2.1, we are now able to provide the definition of dynamic signature for coherent systems with i.i.d. discrete-time components.
Definition 2.2. Let  $\boldsymbol{s}$ be the discrete-time signature of a coherent system with
 $n$ i.i.d. components as in Definition 2.1. Then, if the system is working right after time
 $t$ with
 $j_1,\ldots,j_k$ successive component failures before/at time
 $t$ (
 $t\ge k$), the discrete-time dynamic signature of the system can be defined as
 \begin{equation*}{\boldsymbol{s}}_{j_1,\ldots,j_k} = \left( {{s_{i}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}},{{\rm ~}} j_{k+1} +\cdots +j_m= n-j_{(k)},{{\rm ~}}k+1\le i\le m\le n+k-j_{(k)}} \right),\end{equation*}
where
 \begin{equation*}{s_{i}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}} = P( T = {X_{j_{(i-1)}+1 :n}}|{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}},{{\rm ~}} T \gt t),\end{equation*}
with  $1\le j_1+\cdots+j_{k}\le n-1$.
Remark 2.2. The definition of discrete-time dynamic signature here is defined conditional on the event  $E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}$, that is, the failure pattern among all the components before/at/after observation time
 $t$. However, one can alternatively consider a definition conditional on event
 $E_{j_1,\ldots,j_k,t}$ given the pattern of failures only before/at observation time
 $t$. However, the earlier given definition is more natural than the latter as it facilitates stochastic representations, mixture forms, stochastic orders, extended signatures, and so on. Even though each element of
 $\boldsymbol{s}_{j_1,\ldots,j_k}$ depends on the future tie pattern after time
 $t$, related information is not necessary for
 $\boldsymbol{s}_{j_1,\ldots,j_k}$ since all possible cases are contained in it.
Remark 2.3. Note that for  $k+1\le i\le m$, if
 $P({{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}}, {{\rm ~}} T \gt t) \gt 0$ for some
 $t\ge k$, namely,
 ${\sum\nolimits_{i = k+1}^{m} {s_{i}^{j_1,\ldots,j_m}} } \gt 0$, we have,
 \begin{align*}
{s_{i}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}} =& P( T = {X_{j_{(i-1)}+1 :n}}|{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}}, {{\rm ~}} T \gt t)\cr
=&{ P( T = {X_{j_{(i-1)}+1 :n}},{{\rm ~}}{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}}, {{\rm ~}} T \gt t)}\over{ P( {{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}}, {{\rm ~}} T \gt t)}\cr
=&{ P(T = {X_{j_{(i-1)}+1 :n}} \gt t|{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}})}\over{ P( T \gt t|{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}})}\cr
=&{{ { {s_{i}^{j_1,\ldots,j_m}} }}\over{ {\sum\limits_{i = k+1}^{m} {s_{i}^{j_1,\ldots,j_m}} }}},
\end{align*}
which depends on  $j_1,\ldots,j_k$ only through
 $j_{(k)}=j_1+\cdots+j_k$ since according to Remark 3.1 of [Reference Balakrishnan, Yi and Goroncy3],
 \begin{equation*}{s_{i}^{j_1,\ldots,j_m}}=\sum\limits_{l=j_{(i-1)}+1}^{j_{(i)}}{s_{l}^{1,\ldots,n}}.\end{equation*}
This means that the discrete-time dynamic signature  ${\boldsymbol{s}}_{j_1,\ldots,j_k}$ depends on
 $j_1,\ldots,j_k$ only through
 $j_{(k)}$. Besides, based on the discussions above and the one-to-one relationship of discrete-time signature and the corresponding continuous-time signature as mentioned in Remark 3.1 of [Reference Balakrishnan, Yi and Goroncy3], the discrete-time dynamic signature can be evaluated by using the efficient algorithms available for continuous-time signature in the existing literature [Reference Yi and Cui27]. For example, consider an
 $r$-out-of-
 $n$: F system; its continuous-time signature can be given as
 $\boldsymbol{s}^{(r:n)}=(\underbrace{0,\ldots,0}_{r-1},1,\underbrace{0,\ldots,0}_{n-r})$ directly, which means its discrete-time signature can be given as
 $\boldsymbol{s}^{(r:n)}=(s_{i,(r:n)}^{j_1,\ldots,j_m},{{\rm ~}}j_1+\cdots+j_m=n,{{\rm ~}}1\le i\le m\le n)$ with
 $s_{i,(r:n)}^{j_1,\ldots,j_m}=I_{\{j_{(i-1)} \lt r\le j_{(i)}\}}$. Here,
 $I_{\{A\}}$ is an indicator function such that
 $I_{\{A\}}=1$ if condition
 $A$ is satisfied and
 $I_{\{A\}}=0$ otherwise. Then, its discrete-time dynamic signature can be given as
 \begin{equation*}{\boldsymbol{s}}^{(r:n)}_{j_1,\ldots,j_k} = \left( {{s_{i,(r:n)}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}},{{\rm ~}} j_{k+1} +\cdots +j_m= n-j_{(k)},{{\rm ~}}k+1\le i\le m\le n+k-j_{(k)}} \right),\end{equation*}
with
 \begin{equation*}{s_{i,(r:n)}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}}={{ { {s_{i,(r:n)}^{j_1,\ldots,j_m}} }}\over{ {\sum\limits_{i = k+1}^{m} {s_{i,(r:n)}^{j_1,\ldots,j_m}} }}}={{I_{\{j_{(i-1)} \lt r\le j_{(i)}\}}}\over{\sum\limits_{i = k+1}^{m} I_{\{j_{(i-1)} \lt r\le j_{(i)}\}}}}={{I_{\{j_{(i-1)} \lt r\le j_{(i)}\}}}\over{ I_{\{j_{(k)} \lt r\le j_{(m)}\}}}}={I_{\{j_{(i-1)} \lt r\le j_{(i)}\}}}.\end{equation*}
For a general coherent system with continuous-time signature  $\boldsymbol{s}=(s_1,\ldots,s_n)$, its discrete-time signature can be given as
 $\boldsymbol{s} =(s_i^{j_1,\ldots,j_m},{{\rm ~}}j_1+\cdots+j_m=n,{{\rm ~}}1\le i\le m\le n)$ with
 \begin{equation*}s_{i}^{j_1,\ldots,j_m}=\sum\limits_{u = j_{(i-1)}+1}^{j_{(i)}}s_{u}^{1,\ldots,n}=\sum\limits_{u = j_{(i-1)}+1}^{j_{(i)}}s_{u},\end{equation*}
by regarding it as a mixture of several  $r$-out-of-
 $n$: F systems, which means its discrete-time dynamic signature can be given as
 \begin{equation*}{\boldsymbol{s}}_{j_1,\ldots,j_k} = \left( {{s_{i}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}},{{\rm ~}} j_{k+1} +\cdots +j_m= n-j_{(k)},{{\rm ~}}k+1\le i\le m\le n+k-j_{(k)}} \right),\end{equation*}
with
 \begin{equation*}{s_{i}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}}={{ { {s_{i}^{j_1,\ldots,j_m}} }}\over{ {\sum\limits_{i = k+1}^{m} {s_{i}^{j_1,\ldots,j_m}} }}}={{\sum\limits_{u = j_{(i-1)+1}}^{j_{(i)}}s_{u}}\over{\sum\limits_{i = k+1}^{m} {\sum\limits_{u = j_{(i-1)+1}}^{j_{(i)}}s_{u}}}}={{\sum\limits_{u = j_{(i-1)+1}}^{j_{(i)}}s_{u}}\over{\sum\limits_{u = j_{(k)+1}}^{j_{(m)}}s_{u}}}.\end{equation*}
For better understanding of the concept of discrete-time dynamic signature, an illustrative example is provided now. Note that the structure function  $\phi$ is a function that represents the relationship of system state
 $\phi(\boldsymbol{X})$ and the component state vector
 $\boldsymbol{X}=(X_1,\ldots,X_n)$, where
 $X_1,\ldots,X_n,\phi (\boldsymbol{X}) \in \{0,1\}$ for binary-state systems.
Example 2.1. For a coherent system with structure function
 \begin{equation*}\phi(\boldsymbol{X})=\min(\max(X_1,X_2),\max(X_3,X_4))\end{equation*}
with four i.i.d. discrete-time components, according to Example 3.3 in Balakrishnan et al. [Reference Balakrishnan, Yi and Goroncy3], its discrete-time signature can be given as
 \begin{equation*}{\boldsymbol{s}}=\left( {\begin{matrix}
{s_1^{1,1,1,1}} & {s_2^{1,1,1,1}} & {s_3^{1,1,1,1}} & {s_4^{1,1,1,1}} \cr
{s_1^{1,1,2}} & {s_2^{1,1,2}} & {s_3^{1,1,2}} & {0} \cr
{s_1^{1,2,1}} & {s_2^{1,2,1}} & {s_3^{1,2,1}} & {0} \cr
{s_1^{2,1,1}} & {s_2^{2,1,1}} & {s_3^{2,1,1}} & {0} \cr
{s_1^{1,3}} & {s_2^{1,3}} & {0} & {0} \cr
{s_1^{2,2}} & {s_2^{2,2}} & {0} & {0} \cr
{s_1^{3,1}} & {s_2^{3,1}} & {0} & {0} \cr
{s_1^4} & {0} & {0} & {0} \end{matrix}} \right) = \left( {\begin{matrix}
0 & {1/3} & {2/3} & 0 \cr
0 & {1/3} & {2/3} & {0} \cr
0 & 1 & 0 & {0} \cr
{1/3} & {2/3} & 0 & {0} \cr
0 & 1 & {0} & {0} \cr
{1/3} & {2/3} & {0} & {0} \cr
1 & 0 & {0} & {0} \cr
1 & {0} & {0} & {0} \end{matrix}} \right).\end{equation*}
(1) For the case that the system is working at time  $t$ (
 $t\ge 1$) with
 $j_1=1$ component failure, the discrete-time dynamic signature can be given as
 \begin{align*}
{\boldsymbol{s}}_{1} =& \left( {{s_{i}^{1|j_{2},\ldots,j_{m}}},{{\rm ~}} j_{2} +\cdots +j_m= 3,{{\rm ~}}2\le i\le m\le 4} \right)
=\left( {\begin{matrix}
{s_2^{1|1,1,1}} & {s_3^{1|1,1,1}} & {s_4^{1|1,1,1}} \cr
{s_2^{1|1,2}} & {s_3^{1|1,2}} & {0} \cr
{s_2^{1|2,1}} & {s_3^{1|2,1}} & {0} \cr
{s_2^{1|3}} & {0} & {0} \end{matrix}} \right) \cr
=&\left( {\begin{matrix}
{s_2^{1,1,1,1}}\over{s_2^{1,1,1,1}+s_3^{1,1,1,1}+s_4^{1,1,1,1}} & {s_3^{1,1,1,1}}\over{s_2^{1,1,1,1}+s_3^{1,1,1,1}+s_4^{1,1,1,1}} & {s_4^{1,1,1,1}}\over{s_2^{1,1,1,1}+s_3^{1,1,1,1}+s_4^{1,1,1,1}} \cr
{s_2^{1,1,2}}\over{s_2^{1,1,2}+s_3^{1,1,2}} & {s_3^{1,1,2}}\over{s_2^{1,1,2}+s_3^{1,1,2}} & {0} \cr
{s_2^{1,2,1}}\over{s_2^{1,2,1}+s_3^{1,2,1}} & {s_3^{1,2,1}}\over{s_2^{1,2,1}+s_3^{1,2,1}} & {0} \cr
{s_2^{1,3}}\over{s_2^{1,3}} & {0} & {0} \end{matrix}} \right)
= \left( {\begin{matrix}
{1/3} & {2/3} & 0 \cr
{1/3} & {2/3} & {0} \cr
1 & 0 & {0} \cr
1 & {0} & {0} \end{matrix} } \right),
\end{align*}
which is exactly the discrete-time signature of a system 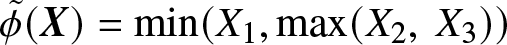 $\tilde \phi(\boldsymbol{X})=\min(X_1,\max(X_2, \ X_3))$ with three i.i.d. discrete-time components;
(2) For the case that the system is working at time  $t$ (
 $t\ge 1$) with
 $j_1=2$ component failures, the discrete-time dynamic signature can be given as
 \begin{align*}
{\boldsymbol{s}}_{2} =& \left( {{s_{i}^{2|j_{2},\ldots,j_{m}}},{{\rm ~}} j_{2} +\cdots +j_m= 2,{{\rm ~}}2\le i\le m\le 3} \right)\end{align*}
 \begin{align*}
\ \ \ \ \ \ \ \ \ \ \ \ \ \ \ =&\left( {\begin{matrix}
{s_2^{2|1,1}} & {s_3^{2|1,1}} \cr
{s_2^{2|2}} & 0 \cr \end{matrix}} \right) =\left( {\begin{matrix}
{s_2^{2,1,1}}\over{s_2^{2,1,1}+s_3^{2,1,1}} & {s_3^{2,1,1}}\over{s_2^{2,1,1}+s_3^{2,1,1}} \cr
{s_2^{2,2}}\over{s_2^{2,2}} & {0} \end{matrix}} \right) = \left( {\begin{matrix}
{1} & {0} \cr
1 & 0 \end{matrix} } \right),
\end{align*}
which is exactly the discrete-time signature of a series system  $\tilde \phi(\boldsymbol{X})=\min(X_1,X_2)$ with two i.i.d. discrete-time components;
(3) For the case that the system is working at time  $t$ (
 $t\ge 2$) with
 $j_1=1,{{\rm ~}}j_2=1$ successive component failures, the discrete-time dynamic signature can be given as
 \begin{align*}
{\boldsymbol{s}}_{1,1} =& \left( {{s_{i}^{1,1|j_{3},\ldots,j_{m}}},{{\rm ~}} j_{3} +\cdots +j_m= 2,{{\rm ~}}3\le i\le m\le 4} \right)\cr
=&\left( {\begin{matrix}
{s_3^{1,1|1,1}} & {s_4^{1,1|1,1}} \cr
{s_3^{1,1|2}} & {0} \cr \end{matrix}} \right) =\left( {\begin{matrix}
{s_3^{1,1,1,1}}\over{s_3^{1,1,1,1}+s_4^{1,1,1,1}} & {s_4^{1,1,1,1}}\over{s_3^{1,1,1,1}+s_4^{1,1,1,1}} \cr
{s_3^{1,1,2}}\over{s_3^{1,1,2}} & {0} \end{matrix}} \right) = \left( {\begin{matrix}
{1} & {0} \cr
1 & 0 \end{matrix} } \right),
\end{align*}
which is exactly the same as in (2);
(4) For the cases that the system is working at time  $t$ with
 $j_1=j_2=j_3=1$ or
 $j_1=1,j_2=2$ or
 $j_1=2,j_2=1$ or
 $j_1=3$ successive component failures, the discrete-time dynamic signature does not exist since the system must be in a failed state with three failed components.
Discrete-time dynamic signature can be further illustrated by generalizing the concept of residual signature in Lindqvist and Samaniego [Reference Lindqvist and Samaniego12] to the discrete-time case.
Definition 2.3. Let  $\boldsymbol{s}$ be the discrete-time signature of a coherent system with
 $n$ i.i.d. components as in Definition 2.1. Then, given a subset
 $\{\pi_1,\ldots,\pi_{j_{(k)}}\}$ of failed components before/at time
 $t$, if the system is still working right after time
 $t$, its discrete-time residual signature can be defined as the discrete-time signature of the residual system by removing components
 $\pi_1,\ldots,\pi_{j_{(k)}}$, that is,
 \begin{equation*}{\boldsymbol{s}}^{(res)}_{\pi_1,\ldots,\pi_{j_{(k)}}} = \left( {{s_{i,(res)}^{{\pi_1,\ldots,\pi_{j_{(k)}}}|j_{1},\ldots,j_{m}}},{{\rm ~}} j_{1} +\cdots +j_m= n-j_{(k)},{{\rm ~}}1\le i\le m\le n-j_{(k)}} \right),\end{equation*}
where  ${s_{i,(res)}^{{\pi_1,\ldots,\pi_{j_{(k)}}}|j_{k+1},\ldots,j_{m}}} = P(T_{\pi_1,\ldots,\pi_{j_{(k)}}}^{(res)} = {\tilde X_{j_{(i-1)}+1 :n-j_{(k)}}}|{{\tilde E_{j_{1},\ldots,j_m}}})$ with
 $1\le j_{(k)}\le n-1$. Here,
 $T_{\pi_1,\ldots,\pi_{j_{(k)}}}^{(res)}$ is the residual system lifetime, and
 $\tilde X_1,\ldots,\tilde X_{n-j_{(k)}}$ are the residual component lifetimes with their related notations defined in a similar way as in Definition 2.1.
Remark 2.4. The discrete-time dynamic signature can be given as an average of all possible discrete-time residual signatures, that is,
 \begin{align*}
{\boldsymbol{s}}_{j_1,\ldots,j_{k}} =&{{N^{ - 1}_{j_{(k)}}}}\sum\limits_{A\in{\{1,\ldots,n\}},{{\rm ~}}|A|=j_{(k)},{{\rm ~}}\phi(\boldsymbol{1}_{A^c},\boldsymbol{0}_A)=1}{\boldsymbol{s}}^{(res)}_{A} ={{N^{ - 1}_{j_{(k)}}}}\sum\limits_{{\{\pi_1,\ldots,\pi_{j_{(k)}}\}}\in{\{1,\ldots,n\}}}{\boldsymbol{s}}^{(res)}_{\pi_1,\ldots,\pi_{j_{(k)}}},
\end{align*}
where  $|A|$ is the size of set
 $A$, and
 ${{N_{j_{(k)}}}}\ge 1$ is the number of possible component subsets
 $A$ of size
 $j_{(k)}$ such that
 $\phi(\boldsymbol{1}_{A^c},\boldsymbol{0}_A)=1$ (namely, the system is working when components in
 $A$ are all failed and other components are all working), for which case
 ${\boldsymbol{s}}^{(res)}_A\ne \boldsymbol{0}$ (denote
 ${\boldsymbol{s}}^{(res)}_A = \boldsymbol{0}$ otherwise just for computation). This is because each subset
 $A$ is chosen from the set
 $\{{1,\ldots,n} \}$ with the same probability
 $\left( {\begin{matrix}
n \cr
{{j_{(k)}}} \end{matrix} } \right)^{-1}$, and the discrete-time dynamic signature is defined given the fact that the system is still working given the
 $j_{(k)}$ failed components, whose probability should be
 ${{N_{j_{(k)}}}}\left( {\begin{matrix}
n \cr
{{j_{(k)}}} \end{matrix} } \right)^{-1}$, namely,
 \begin{align*}
s_i^{j_1,\ldots,j_k|j_{k+1},\ldots,j_m} =&{\sum\limits_{\{{\pi_1,\ldots,\pi_{j_{(k)}}} \}\in{\{1,\ldots,n\}}}s_{i,(res)}^{\pi_1,\ldots,\pi_{j_{(k)}}|j_{k+1},\ldots,j_m} \cdot{\left( {\begin{matrix}
n \cr
{{j_{(k)}}} \end{matrix} } \right)^{-1}}\over{{{N_{j_{(k)}}}}} \left( {\begin{matrix}
n \cr
{{j_{(k)}}} \end{matrix} } \right)^{-1}}\cr
=&{{N^{ - 1}_{j_{(k)}}}}\sum\limits_{\{{\pi_1,\ldots,\pi_{j_{(k)}}} \}\in{\{1,\ldots,n\}}}s_{i,(res)}^{\pi_1,\ldots,\pi_{j_{(k)}}|j_{k+1},\ldots,j_m} . \end{align*}
For a clearer understanding of the concept of discrete-time residual signature and its relationship with discrete-time dynamic signature, an illustrative example is provided now.
Example 2.2. Consider the system in Example 2.1, and then for the case that the system is working with one failed component, we have:
(1) If the failed component is Component 1, then the discrete-time signature of the residual system  $\phi^{(res)}_1(\boldsymbol{X})=\min(X_2,\max(X_3,X_4))$ can be given as
 \begin{align*}
&{\boldsymbol{s}}_1^{(res)} = \left( {\begin{matrix}
{s_{2, (res)}^{1|1,1,1}} & {s_{3, (res)}^{1|1,1,1}} & {s_{4, (res)}^{1|1,1,1}} \cr
{s_{2, (res)}^{1|1,2}} & {s_{3, (res)}^{1|1,2}} & {0} \cr
{s_{2, (res)}^{1|2,1}} & {s_{3, (res)}^{1|2,1}} & {0} \cr
{s_{2, (res)}^{1|3}} & {0} & {0} \end{matrix}} \right) = \left( {\begin{matrix}
{1/3} & {2/3} & 0 \cr
{1/3} & {2/3} & {0} \cr
1 & 0 & {0} \cr
1 & {0} & {0} \end{matrix} } \right).
\end{align*}
(2) The same discussions can also be applied to other cases, namely, if the failed component is Component 2 or 3 or 4, we have the same discrete-time residual signature  ${\boldsymbol{s}}_1^{(res)} ={\boldsymbol{s}}_2^{(res)} ={\boldsymbol{s}}_3^{(res)} ={\boldsymbol{s}}_4^{(res)}$.
From the above discussions, discrete-time dynamic signature of the system can be given by Remark 2.4 as  ${\boldsymbol{s}}_1 ={1\over 4}\sum\nolimits_{i=1}^4{\boldsymbol{s}}_i^{(res)}$, which is exactly the same as in Part (1) of Example 2.1.
The discrete-time dynamic signature is useful in the engineering practice of burn-in. Actually, to prove that a system after burn-in is better than the original system, we only need to compare their discrete-time (dynamic) signatures in the sense of stochastic ordering with the help of transformation formula.
Example 2.3. Consider the system in Example 2.1, for the case that the system is working at time  $t$ with
 $j_1=1$ component failure. Similar to Example 5.1 in Balakrishnan et al. [Reference Balakrishnan, Yi and Goroncy3], the discrete-time signature of its equivalent system of size 4 can be given as
 \begin{align*}
\tilde{\boldsymbol{s}}_1&=\left( {\begin{matrix}
{\tilde s_1^{1,1,1,1}} & {\tilde s_2^{1,1,1,1}} & {\tilde s_3^{1,1,1,1}} & {\tilde s_4^{1,1,1,1}} \cr
{\tilde s_1^{1,1,2}} & {\tilde s_2^{1,1,2}} & {\tilde s_3^{1,1,2}} & {0} \cr
{\tilde s_1^{1,2,1}} & {\tilde s_2^{1,2,1}} & {\tilde s_3^{1,2,1}} & {0} \cr
{\tilde s_1^{2,1,1}} & {\tilde s_2^{2,1,1}} & {\tilde s_3^{2,1,1}} & {0} \cr
{\tilde s_1^{1,3}} & {\tilde s_2^{1,3}} & {0} & {0} \cr
{\tilde s_1^{2,2}} & {\tilde s_2^{2,2}} & {0} & {0} \cr
{\tilde s_1^{3,1}} & {\tilde s_2^{3,1}} & {0} & {0} \cr
{\tilde s_1^4} & {0} & {0} & {0} \end{matrix}} \right)\cr
&=\left( {\begin{matrix}
{3\over 4}{s_2^{1|1,1,1}} & {1\over 4}{s_2^{1|1,1,1}}+{1\over 2}{s_3^{1|1,1,1}} & {1\over 2}{s_3^{1|1,1,1}} +{1\over 4}{s_4^{1|1,1,1}}& {3\over 4}{s_4^{1|1,1,1}} \cr
{1\over 2}{s_2^{1|1,1,1}}+{1\over 4}{s_2^{1|1,2}} & {1\over 2}{s_3^{1|1,1,1}}+{1\over 4}{s_2^{1|1,2}} & {1\over 2}{s_4^{1|1,1,1}}+{1\over 2}{s_3^{1|1,2}} & {0} \cr
{1\over 2}{s_2^{1|1,1,1}}+{1\over 4}{s_2^{1|1,2}} & {1\over 2}{s_3^{1|1,1,1}}+{1\over 4}{s_2^{1|2,1}}+{1\over 4}{s_3^{1|1,2}} & {1\over 2}{s_4^{1|1,1,1}}+{1\over 4}{s_3^{1|2,1}} & {0} \cr
{1\over 2}{s_2^{1|1,1,1}}+{1\over 2}{s_2^{1|2,1}} & {1\over 2}{s_3^{1|1,1,1}}+{1\over 4}{s_3^{1|2,1}} & {1\over 2}{s_4^{1|1,1,1}}+{1\over 4}{s_3^{1|2,1}} & {0} \cr
{3\over 4}{s_2^{1|1,2}} & {3\over 4}{s_3^{1|1,2}}+{1\over 4}{s_2^{1|3}} & {0} & {0} \cr
{1\over 2}{s_2^{1|1,2}}+{1\over 2}{s_2^{1|2,1}} & {1\over 2}{s_3^{1|1,2}}+{1\over 2}{s_3^{1|2,1}} & {0} & {0} \cr
{3\over 4}{s_2^{1|2,1}}+{1\over 4}{s_2^{1|3}} & {3\over 4}{s_3^{1|2,1}} & {0} & {0} \cr
{s_2^{1|3}} & {0} & {0} & {0} \end{matrix}} \right)\cr
&=\left( {\begin{matrix}
{3\over 4}\times{1\over 3} & {1\over 4}\times{1\over 3}+{1\over 2}\times{2\over3} & {1\over 2}\times{2\over3} +{1\over 4}\times 0& {3\over 4}\times 0 \cr
{1\over 2}\times{1\over 3}+{1\over 4}\times{1\over3} & {1\over 2}\times{2\over3}+{1\over 4}\times{1\over3} & {1\over 2}\times 0+{1\over 2}\times{2\over3} & {0} \cr
{1\over 2}\times{1\over 3}+{1\over 4}\times{1\over3} & {1\over 2}\times{2\over3}+{1\over 4}\times 1+{1\over 4}\times{2\over3} & {1\over 2}\times 0+{1\over 4}\times 0 & {0} \cr
{1\over 2}\times{1\over 3}+{1\over 2}\times 1 & {1\over 2}\times{2\over3}+{1\over 4}\times 0 & {1\over 2}\times 0+{1\over 4}\times 0 & {0} \cr
{3\over 4}\times{1\over3} & {3\over 4}\times{2\over3}+{1\over 4}\times 1 & {0} & {0} \cr
{1\over 2}\times{1\over3}+{1\over 2}\times 1 & {1\over 2}\times{2\over 3}+{1\over 2}\times 0 & {0} & {0} \cr
{3\over 4}\times 1+{1\over 4}\times 1 & {3\over 4}\times 0 & {0} & {0} \cr
1 & {0} & {0} & {0} \end{matrix}} \right)=\left( {\begin{matrix}
{1\over 4} & {5\over 12} & {1\over3} & 0 \cr
{1\over 4} & {5\over 12} & {1\over3} & {0} \cr
{1\over4} & {3\over 4} & 0 & {0} \cr
{2\over 3} & {1\over 3} & 0 & {0} \cr
{1\over 4} & {3\over 4} & {0} & {0} \cr
{2\over 3} & {1\over 3} & {0} & {0} \cr
1 & 0 & {0} & {0} \cr
1 & {0} & {0} & {0} \end{matrix}} \right).
\end{align*}
Note that the system after burn-in is worse than the original system because the first row  $({1\over 4},{5\over 12},{1\over 3},{0})$ in its discrete-time dynamic signature is less than the first row
 $(0,{1\over 3},{2\over 3},0)$ in discrete-time signature of the original system in stochastic ordering, namely,
 $({1\over 4},{5\over 12},{1\over 3},{0})\le _{st} (0,{1\over 3},{2\over 3},0)$, which means burn-in should not be carried out in this case according to Remark 4.1 in [Reference Balakrishnan, Yi and Goroncy3]. Note that for signatures
 $\boldsymbol{s}=(s_1,\ldots,s_n)$ and
 $\tilde{\boldsymbol{s}}=(\tilde s_1,\ldots,\tilde s_n)$, stochastic ordering
 $\boldsymbol{s}\le_{st} \tilde{\boldsymbol{s}}$ means
 $\sum\nolimits_{l=i+1}^{n}s_i\le \sum\nolimits_{l=i+1}^{n} \tilde s_i$ for
 $i=1,\ldots,n-1$.
Remark 2.5. If the system in Example 2.1 is replaced by a coherent system with discrete-time signature
 \begin{align*}
{\boldsymbol{s}}=\left( {\begin{matrix}
{s_1^{1,1,1,1}} & {s_2^{1,1,1,1}} & {s_3^{1,1,1,1}} & {s_4^{1,1,1,1}} \cr
{s_1^{1,1,2}} & {s_2^{1,1,2}} & {s_3^{1,1,2}} & {0} \cr
{s_1^{1,2,1}} & {s_2^{1,2,1}} & {s_3^{1,2,1}} & {0} \cr
{s_1^{2,1,1}} & {s_2^{2,1,1}} & {s_3^{2,1,1}} & {0} \cr
{s_1^{1,3}} & {s_2^{1,3}} & {0} & {0} \cr
{s_1^{2,2}} & {s_2^{2,2}} & {0} & {0} \cr
{s_1^{3,1}} & {s_2^{3,1}} & {0} & {0} \cr
{s_1^4} & {0} & {0} & {0} \end{matrix}} \right) =& \left( {\begin{matrix}
s_1 & s_2 & s_3 & s_4 \cr
s_1 & s_2 & s_3+s_4 & {0} \cr
s_1 & s_2+s_3 & s_4 & {0} \cr
s_1+s_2 & s_3 & s_4 & {0} \cr
s_1 & s_2+s_3+s_4 & {0} & {0} \cr
s_1+s_2 & s_3+s_4 & {0} & {0} \cr
s_1+s_2+s_3 & s_4 & {0} & {0} \cr
1 & {0} & {0} & {0} \end{matrix}} \right),
\end{align*}
for the case that the system is working at time  $t$ with
 $j_1=1$ component failure (here,
 $s_1,s_2,s_3,s_4\ge 0,{{\rm ~}}s_1+s_2+s_3+s_4=1$), the discrete-time dynamic signature can be given as
 \begin{align*}
{\boldsymbol{s}}_{1}
=\left( {\begin{matrix}
{s_2^{1|1,1,1}} & {s_3^{1|1,1,1}} & {s_4^{1|1,1,1}} \cr
{s_2^{1|1,2}} & {s_3^{1|1,2}} & {0} \cr
{s_2^{1|2,1}} & {s_3^{1|2,1}} & {0} \cr
{s_2^{1|3}} & {0} & {0} \end{matrix}} \right)
=\left( {\begin{matrix}
{s_2}\over{s_2+s_3+s_4} & {s_3}\over{s_2+s_3+s_4} & {s_4}\over{s_2+s_3+s_4} \cr
{s_2}\over{s_2+s_3+s_4} & {s_3+s_4}\over{s_2+s_3+s_4} & {0} \cr
{s_2+s_3}\over{s_2+s_3+s_4} & {s_4}\over{s_2+s_3+s_4} & {0} \cr
{1} & {0} & {0} \end{matrix}} \right) .
\end{align*}
The discrete-time signature  $\tilde{\boldsymbol{s}}_1$ of its equivalent system of size 4 can be given in the same way, which means similar to Example 2.3, burn-in should be carried out if and only if
 \begin{align*}
(s_1,s_2,s_3,s_4)&\le _{st}\left({3\over 4}{s_2^{1|1,1,1}},
{1\over 4}{s_2^{1|1,1,1}}+{1\over 2}{s_3^{1|1,1,1}},
{1\over 2}{s_3^{1|1,1,1}} +{1\over 4}{s_4^{1|1,1,1}},
{3\over 4}{s_4^{1|1,1,1}}\right) \cr
&={{1}\over{4(s_2+s_3+s_4)}} \cdot (3s_2,s_2+2s_3,2s_3+s_4,3s_4).
\end{align*}
In practice, we are often interested in the residual lifetime distribution of a working system, given the number of failed components before/at the observation time. Now, let us turn to the study of conditional distribution of a system given the  $(r+1,\ldots,r+N)$th component failure
 $(N\ge 1)$ at time
 $x\ge 1$.
Theorem 2.1 Let  $\boldsymbol{s}$ be the discrete-time signature of a coherent system with
 $n$ i.i.d. components as in Definition 2.1 such that
 $s_i^{j_1,\ldots,j_m}=0$ for all
 $j_1+\cdots+j_i \lt l$. Then, the pmf of conditional residual system lifetime
 $(T-x|X_{(r+1,\ldots,r+N):n}=x)$ for
 $1\le r+1 \lt \cdots \lt r+N \lt l$ and
 $x\ge 1$ can be given as
 \begin{align*}
&P(T-x=t| X_{(r+1,\ldots,r+N):n}=x)\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i=1}^m s_i^{j_1,\ldots,j_m} \cdot P(X_{j_{(i-1)}+1:n}=x+t,{{\rm ~}}E_{j_1,\ldots,j_m}|X_{(r_1,\ldots,r_N):n}=x),{{\rm ~}}t\ge 1.
\end{align*}
Proof. The joint pmf of  $(T,X_{(r+1,\ldots,r+N):n})$ can be given as
 \begin{align*}
&P(T=t,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x)\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i=1}^m P(T=t,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x|T=X_{j_{(i-1)}+1:n},{{\rm ~}}E_{j_1,\ldots,j_m})\cr
&\times P(T=X_{j_{(i-1)}+1:n},{{\rm ~}}E_{j_1,\ldots,j_m})\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i=1}^m P(X_{j_{(i-1)}+1:n}=t,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x|T=X_{j_{(i-1)}+1:n},{{\rm ~}}E_{j_1,\ldots,j_m})\cr
&\times P(T=X_{j_{(i-1)}+1:n}|E_{j_1,\ldots,j_m}) P(E_{j_1,\ldots,j_m})\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i=1}^m P(X_{j_{(i-1)}+1:n}=t,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x|E_{j_1,\ldots,j_m})\cdot s_i^{j_1,\ldots,j_m}\cdot P(E_{j_1,\ldots,j_m})\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i=1}^m s_i^{j_1,\ldots,j_m} \cdot P(X_{j_{(i-1)}+1:n}=t,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x,{{\rm ~}}E_{j_1,\ldots,j_m}), {{\rm ~}} t\ge x+1,
\end{align*}
which implies that the pmf of  $(T-x|X_{(r+1,\ldots,r+N):n}=x)$ is given by
 \begin{align*}
&P(T-x=t| X_{(r+1,\ldots,r+N):n}=x)={{P(T=x+t,{{\rm ~}} X_{(r+1,\ldots,r+N):n}=x)}\over{P( X_{(r+1,\ldots,r+N):n}=x)}}\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i=1}^m s_i^{j_1,\ldots,j_m} \cdot P(X_{j_{(i-1)}+1:n}=x+t,{{\rm ~}}E_{j_1,\ldots,j_m}|X_{(r+1,\ldots,r+N):n}=x),{{\rm ~}} t\ge 1.
\end{align*}
Remark 2.6. Note that  $P(X_{(r+1,\ldots,r+N):n}=x)={{n!}\over{r!N!(n-r-N)!}}\bar F^{r}(x-)f^N(x)F^{n-r-N}(x)$ and event
 \begin{align*}
&\{X_{j_{(i-1)}+1:n}=x+t,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x,{{\rm ~}}E_{j_1,\ldots,j_m}\}
\end{align*}
can be written as
 \begin{align*}
&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(w)}+1,\ldots,j_{(w+1)}):n}}=x \lt \cdots \lt \cr
&{X_{(j_{(i-1)} +1,\ldots,j_{(i)} ):n}}=x+t \lt \cdots \lt {X_{(j_{(m-1)} +1,\ldots,j_{(m)} ):n}}\},
\end{align*}
where  $r=j_{(w)}$,
 $ r+N=j_{(w+1)}$ and
 $\bar F=1-F$, which leads to the conditional probability
 $P(X_{j_{(i-1)}+1:n}=x+t,{{\rm ~}}E_{j_1,\ldots,j_m}|X_{(r+1,\ldots,r+N):n}=x)$.
More generally, without the assumption that the system can not fail with less than  $l$ component failures, the above residual system lifetime can be considered as follows.
Theorem 2.2 Let  $\boldsymbol{s}_{j_1,\ldots,j_k}$ be the discrete-time dynamic signature of a coherent system with
 $n$ i.i.d. components as in Definition 2.2. If
 $P(E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x) \gt 0$, the pmf of conditional residual system lifetime
 $(T-x|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x)$ for
 $x\ge 1$ can be given as
 \begin{align*}
&P(T-x=t|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x)\cr
=&\sum\limits_{i=k+1}^m {s_{i}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}} P(X_{j_{(i-1)}+1:n}=x+t|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m}), {{\rm ~}}t\ge 1.
\end{align*}
Proof. The pmf of  $(T-x|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x)$ can be given as
 \begin{align*}
&P(T-x=t|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x)\cr
=&\sum\limits_{i=1}^m P(T=X_{j_{(i-1)}+1:n}|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x) P(T=x+t|T=X_{j_{(i-1)}+1:n},\cr
&E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x)\cr
=&\sum\limits_{i=1}^m P(T=X_{j_{(i-1)}+1:n}|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x) P(X_{j_{(i-1)}+1:n}=x+t|T=X_{j_{(i-1)}+1:n} \gt x,\cr
&E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m})\cr
=&\sum\limits_{i=1}^m P(T=X_{j_{(i-1)}+1:n}|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x) P(X_{j_{(i-1)}+1:n}=x+t|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m})\cr
=&\sum\limits_{i=k+1}^m {s_{i}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}} P(X_{j_{(i-1)}+1:n}=x+t|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m}), {{\rm ~}}t\ge 1.
\end{align*}
Remark 2.7. Note that with event  $E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m}$ defined in Remark 2.1, event
 \begin{align*}
&\{X_{j_{(i-1)}+1:n}=x+t, {{\rm ~}}E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m}\}\end{align*}
can be written as
 \begin{align*}
&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(k-1)}+1,\ldots,j_{(k)}):n}}\le x \lt X_{(j_{(k)}+1,\ldots,j_{(k+1)}):n}
\cr
& \lt \cdots \lt {X_{(j_{(i-1)}+1,\ldots,j_{(i)}):n}}=x+t \lt \cdots \lt {X_{(j_{(m-1)}+1,\ldots,j_{(m)}):n}}\}.
\end{align*}
3. Discrete-time dynamic joint signature
For two coherent systems with shared i.i.d. discrete-time components, Yi and Balakrishnan [Reference Yi and Balakrishnan20] generalized the definition of joint signature [Reference Navarro, Samaniego and Balakrishnan15] in the continuous-time case as follows:
Definition 3.1. For two coherent systems  $\phi_1,\phi_2$ with
 $n$ shared components and lifetimes
 $T_1,T_2$, suppose the components have i.i.d. discrete lifetimes
 ${X_1}, \ldots ,{X_n}$ from a cdf
 $F(\cdot)$ and a pmf
 $f(\cdot)$. Denoting the
 $i$th smallest component lifetime by
 ${X_{i:n}}$, the discrete-time joint signature of the systems can be defined as
 \begin{equation*}{\boldsymbol{s}} = \left( {{s_{i_1,i_2}^{j_1,\ldots,j_{m}}},{{\rm ~}} j_1 +\cdots +j_m= n,{{\rm ~}}1\le i_1,i_2\le m\le n} \right),\end{equation*}
where
 \begin{equation*}{s_{i_1,i_2}^{j_1,\ldots,j_m}} = P( T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}}|{{E_{j_1,\ldots,j_m}}}) \end{equation*}
is the conditional probability that failure of System  $\phi_1$ is caused by the
 $(j_{(i_1-1)}+1)$th component failure and failure of System
 $\phi_2$ is caused by the
 $(j_{(i_2-1)}+1)$th component failure, given the event
 ${E_{j_1,\ldots,j_m}}$ in Definition 2.1.
Remark 3.1. Similar to Remark 2.1, for  $1\le k \le m-1$,
 $t\ge k$, we have
 \begin{align*}
&P(T_1 \gt t,{{\rm ~}}T_2 \gt t|{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}})\cr
=& {\sum\limits_{i_1 = 1}^{m}\sum\limits_{i_2 = 1}^{m} {P( T_1 \gt t,{{\rm ~}}T_2 \gt t|T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}},{{\rm ~}}E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}) } } \cr
&\times P( T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}}|{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}) \cr
=& {\sum\limits_{i_1 = 1}^{m}\sum\limits_{i_2 = 1}^{m} {P( {X_{j_{(i_1-1)}+1 :n}} \gt t,{{\rm ~}}{X_{j_{(i_2-1)}+1 :n}} \gt t|T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}}, } } \cr
&E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}) P( T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}}|{E_{j_1,\ldots,j_m}}) \cr
=& {\sum\limits_{i_1 = 1}^{m}\sum\limits_{i_2 = 1}^{m} {P( {X_{j_{(i_1-1)}+1 :n}} \gt t,{{\rm ~}}{X_{j_{(i_2-1)}+1 :n}} \gt t|E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}) } } {s_{i_1,i_2}^{j_1,\ldots,j_m}} \cr
=&{\sum\limits_{i_1 = 1}^{m}\sum\limits_{i_2 = 1}^{m} I_{\{i_1\ge k+1,{{\rm ~}}i_2\ge k+1\}} } {s_{i_1,i_2}^{j_1,\ldots,j_m}}= {\sum\limits_{i_1 = k+1}^{m} \sum\limits_{i_2 = k+1}^{m} {s_{i_1,i_2}^{j_1,\ldots,j_m}} } .
\end{align*}
Based on Remark 3.1, we are now able to provide the definition of dynamic joint signature for coherent systems with i.i.d. discrete-time components.
Definition 3.2. Let  $\boldsymbol{s}$ be the discrete-time joint signature of two coherent systems with
 $n$ shared i.i.d. components as in Definition 3.1. Then, if the systems are both working right after time
 $t$ with
 $j_1,\ldots,j_k$ successive component failures before/at time
 $t$ (
 $t\ge k$), the discrete-time dynamic joint signature of the two systems can be defined as
 \begin{equation*}{\boldsymbol{s}}_{j_1,\ldots,j_k} = \left( {{s_{i_1,i_2}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}},{{\rm ~}} j_{k+1} +\cdots +j_m= n-j_{(k)},{{\rm ~}}k+1\le i_1,i_2\le m\le n+k-j_{(k)}} \right),\end{equation*}
where
 \begin{equation*}{s_{i_1,i_2}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}} = P( T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}}|{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}},{{\rm ~}}T_1 \gt t,{{\rm ~}} T_2 \gt t) \end{equation*}
with  $1\le j_1+\cdots+j_k\le n-1$.
Remark 3.2. Note that in the  $n$ shared components, there can be
 $n_1$ components only in System
 $\phi_1$,
 $n_2$ components only in System
 $\phi_2$ and
 $n_{1,2}$ components in both systems (
 $n_1+n_2+n_{1,2}=n$). For example, if the structure functions of Systems
 $\phi_1,\phi_2$ are
 $\phi_1=\max(X_1,X_2),\phi_2=\min(X_2,X_3)$, respectively, then there are
 $n=3$ shared components in total, in which
 $n_1=1$ component is only in System
 $\phi_1$,
 $n_2=1$ component is only in System
 $\phi_2$ and
 $n_{1,2}=1$ component is in both systems. As in Remark 2.2, the definition of discrete-time dynamic joint signature here is also defined conditional on the event
 $E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}$ instead of
 $E_{j_1,\ldots,j_k,t}$ for the same reason as mentioned before.
Remark 3.3. Note that for  $k+1\le i_1,i_2\le m$, if
 $P({{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}}, {{\rm ~}} T_1 \gt t,{{\rm ~}} T_2 \gt t) \gt 0$ for some
 $t\ge k$, namely,
 ${\sum\nolimits_{i_1 = k+1}^{m} \sum\nolimits_{i_2 = k+1}^{m} {s_{i_1,i_2}^{j_1,\ldots,j_m}} } \gt 0$, we have,
 \begin{align*}
{s_{i_1,i_2}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}}
=& P( T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}}|{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}}, {{\rm ~}} T_1 \gt t, {{\rm ~}} T_2 \gt t)\cr
=&{ P( T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}},{{\rm ~}}{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}}, {{\rm ~}} T_1 \gt t, {{\rm ~}} T_2 \gt t)}\over{ P( {{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}}, {{\rm ~}} T_1 \gt t, {{\rm ~}} T_2 \gt t)}\cr
=&{ P( T_1 = {X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T_2 = {X_{j_{(i_2-1)}+1 :n}}, {{\rm ~}} T_1 \gt t, {{\rm ~}} T_2 \gt t|{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}})}\over{ P( T_1 \gt t, {{\rm ~}} T_2 \gt t|{{E_{j_1,\ldots,j_k,t,j_{k+1},\ldots,j_m}}})}\cr
=&{{ { {s_{i_1,i_2}^{j_1,\ldots,j_m}} }}\over{ {\sum\limits_{i_1 = k+1}^{m} \sum\limits_{i_2 = k+1}^{m} {s_{i_1,i_2}^{j_1,\ldots,j_m}} }}},
\end{align*}
which depends on  $j_1,\ldots,j_k$ only through
 $j_{(k)}=j_1+\cdots+j_k$ since according to Proposition 3.2 of [Reference Yi and Balakrishnan20], we have
 \begin{equation*}{s_{i_1,i_2}^{j_1,\ldots,j_{m}}}=\sum\limits_{l_1 = {j_{(i_1-1)}}+1}^{j_{(i_1)}}\sum\limits_{l_2 = {j_{(i_2-1)}}+1}^{j_{(i_2)}} {s_{l_1,l_2}^{1, \ldots ,n}}.\end{equation*}
This means that the discrete-time dynamic joint signature  ${\boldsymbol{s}}_{j_1,\ldots,j_k}$ depends on
 $j_1,\ldots,j_k$ only through
 $j_{(k)}$. Besides, based on the discussions above and the one-to-one relationship of discrete-time joint signature and the corresponding continuous-time joint signature as mentioned in Proposition 3.2 of [Reference Yi and Balakrishnan20], the discrete-time dynamic joint signature can be evaluated by using efficient algorithms that are available for the continuous-time joint signature. For example, consider an
 $r_1$-out-of-
 $n$: F system and an
 $r_2$-out-of-
 $n$: F system with
 $n$ shared components in both of them; their continuous-time joint signature can be given as
 $\boldsymbol{s}^{(r_1,r_2:n)}=(s_{i_1,i_2}^{(r_1,r_2:n)}, {{\rm ~}}1\le i_1,i_2\le n)$ with
 $s_{i_1,i_2}^{(r_1,r_2:n)}=I_{\{i_1=r_1,{{\rm ~}}i_2=r_2\}}$ directly, which means their discrete-time joint signature can be given as
 \begin{equation*}\boldsymbol{s}^{(r_1,r_2:n)}=(s_{i_1,i_2,(r_1,r_2:n)}^{j_1,\ldots,j_m},{{\rm ~}}j_1+\cdots+j_m=n,{{\rm ~}}1\le i_1,i_2\le m\le n),\end{equation*}
with  $s_{i_1,i_2,(r_1,r_2:n)}^{j_1,\ldots,j_m}=I_{\{j_{(i_1-1)} \lt r_1\le j_{(i_1)},{{\rm ~}}j_{(i_2-1)} \lt r_2\le j_{(i_2)}\}}$. Then, their discrete-time dynamic signature can be given as
 \begin{equation*}{\boldsymbol{s}}^{(r_1,r_2:n)}_{j_1,\ldots,j_k} = \left( {{s_{i_1,i_2,(r_1,r_2:n)}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}},{{\rm ~}} j_{k+1} +\cdots +j_m= n-j_{(k)},{{\rm ~}}k+1\le i_1,i_2\le m\le n+k-j_{(k)}} \right),\end{equation*}
with
 \begin{align*}
{s_{i_1,i_2,(r_1,r_2:n)}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}}&={{ { {s_{i_1,i_2,(r_1,r_2:n)}^{j_1,\ldots,j_m}} }}\over{ {\sum\limits_{i_1 = k+1}^{m} \sum\limits_{i_2 = k+1}^{m} {s_{i_1,i_2,(r_1,r_2:n)}^{j_1,\ldots,j_m}} }}}={{I_{\{j_{(i_1-1)} \lt r_1\le j_{(i_1)},{{\rm ~}}j_{(i_2-1)} \lt r_2\le j_{(i_2)}\}}}\over{\sum\limits_{i_1 = k+1}^{m}\sum\limits_{i_2 = k+1}^{m} I_{\{j_{(i_1-1)} \lt r_1\le j_{(i_1)},{{\rm ~}}j_{(i_2-1)} \lt r_2\le j_{(i_2)}\}}}}\cr
&={{I_{\{j_{(i_1-1)} \lt r_1\le j_{(i_1)},{{\rm ~}}j_{(i_2-1)} \lt r_2\le j_{(i_2)}\}}}\over{ I_{\{j_{(k)} \lt r_1\le j_{(m)},{{\rm ~}}j_{(k)} \lt r_2\le j_{(m)}\}}}}={I_{\{j_{(i_1-1)} \lt r_1\le j_{(i_1)},{{\rm ~}}j_{(i_2-1)} \lt r_2\le j_{(i_2)}\}}}.
\end{align*}
For two general coherent systems with continuous-time joint signature  $\boldsymbol{s}=(s_{i_1,i_2},{{\rm ~}}1\le i_1,i_2\le n)$, their discrete-time joint signature can be given as
 $\boldsymbol{s} =(s_{i_1,i_2}^{j_1,\ldots,j_m},{{\rm ~}}j_1+\cdots+j_m=n,{{\rm ~}}1\le i_1,i_2\le m\le n)$ with
 \begin{equation*}s_{i_1,i_2}^{j_1,\ldots,j_m}=\sum\limits_{u_1 = j_{(i_1-1)}+1}^{j_{(i_1)}} \sum\limits_{u_2 = j_{(i_2-1)}+1}^{j_{(i_2)}} s_{u_1,u_2}^{1,\ldots,n}=\sum\limits_{u_1 = j_{(i_1-1)}+1}^{j_{(i_1)}} \sum\limits_{u_2 = j_{(i_2-1)}+1}^{j_{(i_2)}} s_{u_1,u_2},\end{equation*}
by regarding them as a mixture of several pairs of  $r$-out-of-
 $n$: F systems with
 $n$ shared components in both of them, which means their discrete-time dynamic joint signature can be given as
 \begin{equation*}{\boldsymbol{s}}_{j_1,\ldots,j_k} = \left( {{s_{i}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}},{{\rm ~}} j_{k+1} +\cdots +j_m= n-j_{(k)},{{\rm ~}}k+1\le i\le m\le n+k-j_{(k)}} \right),\end{equation*}
with
 \begin{align*}
{s_{i_1,i_2}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}}=&{{ { {s_{i_1,i_2}^{j_1,\ldots,j_m}} }}\over{ {\sum\limits_{i_1 = k+1}^{m} \sum\limits_{i_2 = k+1}^{m} {s_{i_1,i_2}^{j_1,\ldots,j_m}} }}}={\sum\limits_{u_1 = j_{(i_1-1)}+1}^{j_{(i_1)}} \sum\limits_{u_2 = j_{(i_2-1)}+1}^{j_{(i_2)}} s_{u_1,u_2}\over{ {\sum\limits_{i_1 = k+1}^{m} \sum\limits_{i_2 = k+1}^{m} \sum\limits_{u_1 = j_{(i_1-1)}+1}^{j_{(i_1)}} \sum\limits_{u_2 = j_{(i_2-1)}+1}^{j_{(i_2)}} s_{u_1,u_2}}}}\cr
=&{\sum\limits_{u_1 = j_{(i_1-1)}+1}^{j_{(i_1)}} \sum\limits_{u_2 = j_{(i_2-1)}+1}^{j_{(i_2)}} s_{u_1,u_2}\over{ { \sum\limits_{u_1 = j_{(k)}+1}^{n} \sum\limits_{u_2 = j_{(k)}+1}^{n} s_{u_1,u_2} }}}.
\end{align*}
For a clearer understanding of the concept of discrete-time dynamic joint signature, an illustrative example is provided now.
Example 3.1. For two coherent systems with structure functions
 \begin{equation*}\phi_1(\boldsymbol{X})=\min(\max(X_1,X_2),X_3), {{\rm ~~}}\phi_2(\boldsymbol{X})=\max(\min(X_1,X_2),X_3)\end{equation*}
with three shared i.i.d. discrete-time components, according to Example 3.2 in Yi and Balakrishnan [Reference Yi and Balakrishnan20], their discrete-time joint signature can be given as
 \begin{align*}
{\boldsymbol{s}} =& \left( {\begin{matrix}
{s_{1,1}^{1,1,1}} & {s_{1,2}^{1,1,1}} & {s_{1,3}^{1,1,1}} &
{s_{2,1}^{1,1,1}} & {s_{2,2}^{1,1,1}} & {s_{2,3}^{1,1,1}} &
{s_{3,1}^{1,1,1}} & {s_{3,2}^{1,1,1}} & {s_{3,3}^{1,1,1}} \cr
{s_{1,1}^{1,2}} & {s_{1,2}^{1,2}} &
{s_{2,1}^{1,2}} & {s_{2,2}^{1,2}} &
{0} & {0} & {0} & {0} & {0}\cr
{s_{1,1}^{2,1}} & {s_{1,2}^{2,1}} &
{s_{2,1}^{2,1}} & {s_{2,2}^{2,1}} &
{0} & {0} & {0} & {0} & {0} \cr
{s_{1,1}^3} & {0} & {0} & {0} & {0} & {0} & {0} & {0} & {0} \end{matrix}} \right)\cr
=& \left( {\begin{matrix}
{0} & {1\over3} & {0} &
{0} & {1\over3} & {1\over3} &
{0} & {0} & {0} \cr
{0} & {1\over3} &
{0} & {2\over3} &
{0} & {0} & {0} & {0} & {0}\cr
{2\over3} & {1\over3} &
{0} & {0} &
{0} & {0} & {0} & {0} & {0} \cr
{1} & {0} & {0} & {0} & {0} & {0} & {0} & {0} & {0} \end{matrix}} \right).
\end{align*}
(1) For the case that the systems are working at time  $t$ (
 $t\ge 1$) with
 $j_1=1$ component failure, the discrete-time dynamic joint signature can be given as
 \begin{align*}
{\boldsymbol{s}}_{1} =& \left( {{s_{i_1,i_2}^{1|j_{2},\ldots,j_{m}}},{{\rm ~}} j_{2} +\cdots +j_m= 2,{{\rm ~}}2\le i_1,i_2\le m\le 3} \right)=\left( {\begin{matrix}
{s_{2,2}^{1|1,1}} & {s_{2,3}^{1|1,1}} & {s_{3,2}^{1|1,1}} & {s_{3,3}^{1|1,1}} \cr
{s_{2,2}^{1|2}} & {0} & {0} & {0} \end{matrix}} \right) \cr
=&\left( {\begin{matrix}
{s_{2,2}^{1,1,1}}\over{s_{2,2}^{1,1,1}+s_{2,3}^{1,1,1}+s_{3,2}^{1,1,1}+s_{3,3}^{1,1,1}} & {s_{2,3}^{1,1,1}}\over{s_{2,2}^{1,1,1}+s_{2,3}^{1,1,1}+s_{3,2}^{1,1,1}+s_{3,3}^{1,1,1}} & {s_{3,2}^{1,1,1}}\over{s_{2,2}^{1,1,1}+s_{2,3}^{1,1,1}+s_{3,2}^{1,1,1}+s_{3,3}^{1,1,1}} & {s_{3,3}^{1,1,1}}\over{s_{2,2}^{1,1,1}+s_{2,3}^{1,1,1}+s_{3,2}^{1,1,1}+s_{3,3}^{1,1,1}} \cr
{s_{2,2}^{1,2}}\over{s_{2,2}^{1,2}} & {0} & {0} & {0} \end{matrix}} \right) \cr
=& \left( {\begin{matrix}
{1/2} & {1/2} & 0 &0 \cr
1 & {0} & {0} &0 \end{matrix} } \right),
\end{align*}
which is exactly the discrete-time joint signature of systems  $\tilde \phi_1(\boldsymbol{X})=\min(X_1,X_2)$,
 $\tilde \phi_2(\boldsymbol{X})=X_2$ with two shared i.i.d. components;
(2) For the cases that the systems are working at time  $t$ with
 $j_1=j_2=1$ or
 $j_1=2$ successive component failures, the discrete-time dynamic joint signature does not exist since system
 $\phi_1$ must be in a failed state with two failed components.
The discrete-time dynamic joint signature can be further illustrated by generalizing the concept of residual signature in Section 2 to residual joint signature as follows.
Definition 3.3. Let  $\boldsymbol{s}$ be the discrete-time joint signature of two coherent systems with
 $n$ shared i.i.d. components as in Definition 3.1. Then, given a subset
 $\{\pi_1,\ldots,\pi_{j_{(k)}}\}$ of failed components before/at time
 $t$, if the systems are both working right after time
 $t$, their discrete-time residual joint signature can be defined as the discrete-time joint signature of the residual systems by removing components
 $\pi_1,\ldots,\pi_{j_{(k)}}$, that is,
 \begin{equation*}{\boldsymbol{s}}^{(res)}_{\pi_1,\ldots,\pi_{j_{(k)}}} = \left( {{s_{i_1,i_2,(res)}^{{\pi_1,\ldots,\pi_{j_{(k)}}}|j_{1},\ldots,j_{m}}},{{\rm ~}} j_{1} +\cdots +j_m= n-j_{(k)},{{\rm ~}}1\le i_1,i_2\le m\le n-j_{(k)}} \right),\end{equation*}
where  ${s_{i_1,i_2,(res)}^{{\pi_1,\ldots,\pi_{j_{(k)}}}|j_{1},\ldots,j_{m}}} = P( T^{1,(res)}_{\pi_1,\ldots,\pi_{j_{(k)}}} = {\tilde X_{j_{(i_1-1)}+1 :n}},{{\rm ~}}T^{2,(res)}_{\pi_1,\ldots,\pi_{j_{(k)}}} = {\tilde X_{j_{(i_2-1)}+1 :n}}|{{\tilde E_{j_{1},\ldots,j_m}}})$ with
 $1\le j_{(k)}\le n-1$. Here,
 $T_{\pi_1,\ldots,\pi_{j_{(k)}}}^{1,(res)},T_{\pi_2,\ldots,\pi_{j_{(k)}}}^{1,(res)}$ are the residual system lifetimes, and
 $\tilde X_1,\ldots,\tilde X_{n-j_{(k)}}$ are the residual component lifetimes with their related notations defined in a similar way as in Definition 2.1.
Remark 3.4. As in Remark 2.4, the discrete-time dynamic joint signature can also be given as an average of all possible discrete-time residual joint signatures, that is,
 \begin{align*}
{\boldsymbol{s}}_{j_1,\ldots,j_{k}} &={{N^{ - 1}_{j_{(k)}}}}\sum\limits_{A\in{\{1,\ldots,n\}}, {{\rm ~}}|A|=j_{(k)},{{\rm ~}}\phi_1(\boldsymbol{1}_{A^c},\boldsymbol{0}_A)=\phi_2(\boldsymbol{1}_{A^c},\boldsymbol{0}_A)=1 }{\boldsymbol{s}}^{(res)}_{A} \cr
&={{N^{ - 1}_{j_{(k)}}}}\sum\limits_{\{{\pi_1,\ldots,\pi_{j_{(k)}}} \}\in{\{1,\ldots,n\}}}{\boldsymbol{s}}^{(res)}_{\pi_1,\ldots,\pi_{j_{(k)}}},
\end{align*}
where  $|A|$ is the size of set
 $A$ and
 ${{N_{j_{(k)}}}}\ge 1$ is the number of possible component subsets
 $A$ of size
 $j_{(k)}$ such that
 $\phi_1(\boldsymbol{1}_{A^c},\boldsymbol{0}_A)=\phi_2(\boldsymbol{1}_{A^c},\boldsymbol{0}_A)=1$ (namely, the systems are both working when the components in
 $A$ are all failed and other components are all working), for which case
 ${\boldsymbol{s}}^{(res)}_A\ne \boldsymbol{0}$ (denote
 ${\boldsymbol{s}}^{(res)}_A = \boldsymbol{0}$ otherwise just for computation) This is because each subset
 $A$ is chosen from the set
 $\{{1,\ldots,n} \}$ with the same probability
 $\left( {\begin{matrix}
n \cr
{{j_{(k)}}} \end{matrix} } \right)^{-1}$, and the discrete-time dynamic joint signature is defined given the fact that the two systems are still working given the
 $j_{(k)}$ failed components, whose probability should be
 ${{N_{j_{(k)}}}}\left( {\begin{matrix}
n \cr
{{j_{(k)}}} \end{matrix} } \right)^{-1}$, namely,
 \begin{align*}
s_{i_1,i_2}^{j_1,\ldots,j_k|j_{k+1},\ldots,j_m} =&{\sum\limits_{\{{\pi_1,\ldots,\pi_{j_{(k)}}} \}\in{\{1,\ldots,n\}}}s_{i_1,i_2,(res)}^{\pi_1,\ldots,\pi_{j_{(k)}}|j_{k+1},\ldots,j_m} \cdot{\left( {\begin{matrix}
n \cr
{{j_{(k)}}} \end{matrix} } \right)^{-1}}\over{{{N_{j_{(k)}}}}} \left( {\begin{matrix}
n \cr
{{j_{(k)}}} \end{matrix} } \right)^{-1}}\cr
=&{{N^{ - 1}_{j_{(k)}}}}\sum\limits_{\{{\pi_1,\ldots,\pi_{j_{(k)}}} \}\in{\{1,\ldots,n\}}}s_{i_1,i_2,(res)}^{\pi_1,\ldots,\pi_{j_{(k)}}|j_{k+1},\ldots,j_m} .\end{align*}
For a clearer understanding of the concept of discrete-time residual joint signature and its relationship with discrete-time dynamic joint signature, an illustrative example is provided now.
Example 3.2. Consider the systems in Example 3.1, and then for the case that the systems are working with one failed component, we have:
(1) If the failed component is Component 1, then the discrete-time joint signature of the residual systems  $\phi^{(res)}_1(\boldsymbol{X})=\min(X_2,X_3), {{\rm ~}}\phi^{(res)}_2(\boldsymbol{X})=X_3$ can be given as
 \begin{align*}
&{\boldsymbol{s}}_1^{(res)} = \left( {\begin{matrix}
{s_{2,2(res)}^{1|1,1}} & {s_{2,3,(res)}^{1|1,1}} & {s_{3,2,(res)}^{1|1,1}} & {s_{3,3,(res)}^{1|1,1}} \cr
{s_{2,(res)}^{1|2}} & {0} & {0} & {0} \end{matrix}} \right) = \left( {\begin{matrix}
{1/2} & {1/2} & 0 & 0 \cr
1 & {0} & {0} &0 \end{matrix} } \right);
\end{align*}
(2) If the failed component is Component 2, the discussions should be the same, namely, we have the same discrete-time residual joint signature  ${\boldsymbol{s}}_1^{(res)} ={\boldsymbol{s}}_2^{(res)}$;
(3) The failed component can not be Component 3 since it would lead to the failure of System  $\phi_2$ with probability 1.
From the above discussions, the discrete-time dynamic joint signature of the systems can be given by Remark 3.4 as  ${\boldsymbol{s}}_1 ={1\over 2}\sum\nolimits_{i=1}^2{\boldsymbol{s}}_i^{(res)}$, which is exactly the same as in Part (1) of Example 3.1.
The discrete-time dynamic joint signature is also useful in the engineering practice of burn-in. Actually, to prove that the systems after burn-in are better than the original systems, we only need to compare their discrete-time (dynamic) joint signatures in the sense of stochastic ordering with the help of transformation formula.
Example 3.3. Consider the systems in Example 3.1, for the case that the systems are working at time  $t$ with
 $j_1=1$ component failure. Similar to Example 5.1 in Yi and Balakrishnan [Reference Yi and Balakrishnan20], the discrete-time dynamic joint signature of their equivalent system of size 3 can be given as
 \begin{align*}
{\tilde{\boldsymbol{s}}}_1 =& \left( {\begin{matrix}
{\tilde s_{1,1}^{1,1,1}} & {\tilde s_{1,2}^{1,1,1}} & {\tilde s_{1,3}^{1,1,1}} &
{\tilde s_{2,1}^{1,1,1}} & {\tilde s_{2,2}^{1,1,1}} & {\tilde s_{2,3}^{1,1,1}} &
{\tilde s_{3,1}^{1,1,1}} & {\tilde s_{3,2}^{1,1,1}} & {\tilde s_{3,3}^{1,1,1}} \cr
{\tilde s_{1,1}^{1,2}} & {\tilde s_{1,2}^{1,2}} &
{\tilde s_{2,1}^{1,2}} & {\tilde s_{2,2}^{1,2}} &
{0} & {0} & {0} & {0} & {0}\cr
{\tilde s_{1,1}^{2,1}} & {\tilde s_{1,2}^{2,1}} &
{\tilde s_{2,1}^{2,1}} & {\tilde s_{2,2}^{2,1}} &
{0} & {0} & {0} & {0} & {0} \cr
{\tilde s_{1,1}^3} & {0} & {0} & {0} & {0} & {0} & {0} & {0} & {0} \end{matrix}} \right)\cr
=& \left( {\begin{matrix}
{2\over 3}{s_{2,2}^{1|1,1}}& {1\over 3}{s_{2,3}^{1|1,1}} & {1\over 3}{s_{2,3}^{1|1,1}} &
{1\over 3}{s_{3,2}^{1|1,1}} & {1\over 3}{s_{2,2}^{1|1,1}}+{1\over 3}{s_{3,3}^{1|1,1}} & {1\over 3}{s_{2,3}^{1|1,1}} &
{1\over 3}{s_{3,2}^{1|1,1}} & {1\over 3}{s_{3,2}^{1|1,1}} & {2\over 3}{ s_{3,3}^{1|1,1}} \cr
{2\over 3}{s_{2,2}^{1|1,1}} & {2\over 3}{s_{2,3}^{1|1,1}} &
{2\over 3}{s_{3,2}^{1|1,1}} & {2\over 3}{s_{3,3}^{1|1,1}}+{1\over 3}{s_{2,2}^{1|2}} &
{0} & {0} & {0} & {0} & {0}\cr
{2\over 3}{s_{2,2}^{1|1,1}}+{1\over 3}{s_{2,2}^{1|2}} & {2\over 3}{s_{2,3}^{1|1,1}} &
{2\over 3}{s_{3,2}^{1|1,1}} & {2\over 3}{s_{3,3}^{1|1,1}} &
{0} & {0} & {0} & {0} & {0} \cr
{s_{2,2}^{1|2}} & {0} & {0} & {0} & {0} & {0} & {0} & {0} & {0} \end{matrix}} \right)\cr
=& \left( {\begin{matrix}
{2\over 3}\times{1\over 2} & {1\over 3}\times{1\over 2} & {1\over 3}\times{1\over 2} &
{1\over 3}\times0 & {1\over 3}\times{1\over 2}+{1\over 3}\times{0} & {1\over 3}\times{1\over 2} &
{1\over 3}\times0 & {1\over 3}\times0 & {2\over 3}\times{0} \cr
{2\over 3}\times{1\over 2} & {2\over 3}\times{1\over 2} &
{2\over 3}\times0 & {2\over 3}\times{0}+{1\over 3}\times 1 &
{0} & {0} & {0} & {0} & {0}\cr
{2\over 3}\times{1\over 2}+{1\over 3}\times 1 & {2\over 3}\times{1\over 2} &
{2\over 3}\times0 & {2\over 3}\times{0} &
{0} & {0} & {0} & {0} & {0} \cr
1 & {0} & {0} & {0} & {0} & {0} & {0} & {0} & {0} \end{matrix}} \right)\cr
=& \left( {\begin{matrix}
{1\over 3} & {1\over 6} & {1\over 6} &
0 & {1\over 6} & {1\over 6} &
0 & 0 & 0 \cr
{1\over 3} & {1\over 3} &
0 & {1\over 3} &
{0} & {0} & {0} & {0} & {0}\cr
{2\over 3} & {1\over 3} &
0 & {0} &
{0} & {0} & {0} & {0} & {0} \cr
1 & {0} & {0} & {0} & {0} & {0} & {0} & {0} & {0} \end{matrix}} \right).
\end{align*}
Note that the systems after burn-in are worse than the original systems because the first row  $({1\over 3},{1\over 6},{1\over 6};{0},{1\over 6},{1\over 6};0,0,0)$ in its discrete-time dynamic joint signature is less than the first row
 $(0,{1\over 3},0;\ 0,{1\over 3},{1\over 3};0,0,0)$ in discrete-time joint signature of the original systems in stochastic ordering, namely,
 \begin{equation*} \left(\begin{matrix}
{1\over 3}&{1\over 6}&{1\over 6}\cr
{0}&{1\over 6}&{1\over 6}\cr
0&0&0
\end{matrix}\right)\le_{st} \left(\begin{matrix}
0&{1\over 3}&0\cr
0&{1\over 3}&{1\over 3}\cr 0&0&0
\end{matrix}\right),\end{equation*}
which means burn-in should not be carried out in this case according to Remark 4.1 of [Reference Yi and Balakrishnan20]. Note that for joint signatures  $\boldsymbol{s}=(s_{i_1,i_2},{{\rm ~}}1\le i_1,i_2\le n)$ and
 $\tilde{\boldsymbol{s}}=(\tilde s_{i_1,i_2},{{\rm ~}}1\le i_1,i_2\le n)$, stochastic ordering
 $\boldsymbol{s}\le_{st} \tilde{\boldsymbol{s}}$ means
 $\sum\nolimits_{l_1=i_1+1}^{n}\sum\nolimits_{l_2=i_2+1}^{n}s_{i_1,i_2}\le \sum\nolimits_{l_1=i_1+1}^{n}\sum\nolimits_{l_2=i_2+1}^{n}\tilde s_{i_1,i_2}$ for
 $0\le i_1,i_2\le n-1$.
Remark 3.5. If the systems in Example 3.1 are replaced by two coherent systems with discrete-time joint signature
 \begin{align*}
{\boldsymbol{s}} =& \left( {\begin{matrix}
{s_{1,1}^{1,1,1}} & {s_{1,2}^{1,1,1}} & {s_{1,3}^{1,1,1}} &
{s_{2,1}^{1,1,1}} & {s_{2,2}^{1,1,1}} & {s_{2,3}^{1,1,1}} &
{s_{3,1}^{1,1,1}} & {s_{3,2}^{1,1,1}} & {s_{3,3}^{1,1,1}} \cr
{s_{1,1}^{1,2}} & {s_{1,2}^{1,2}} &
{s_{2,1}^{1,2}} & {s_{2,2}^{1,2}} &
{0} & {0} & {0} & {0} & {0}\cr
{s_{1,1}^{2,1}} & {s_{1,2}^{2,1}} &
{s_{2,1}^{2,1}} & {s_{2,2}^{2,1}} &
{0} & {0} & {0} & {0} & {0} \cr
{s_{1,1}^3} & {0} & {0} & {0} & {0} & {0} & {0} & {0} & {0} \end{matrix}} \right)\cr
=& \left( {\begin{matrix}
{s_{1,1}} & {s_{1,2}} & {s_{1,3}} &
{s_{2,1}} & {s_{2,2}} & {s_{2,3}} &
{s_{3,1}} & {s_{3,2}} & {s_{3,3}} \cr
{s_{1,1}} & {s_{1,2}+s_{1,3}} &
{s_{2,1}+s_{3,1}} & {s_{2,2}+s_{2,3}+s_{3,2}+s_{3,3}} &
{0}&{0} & {0} & {0} & {0}\cr
{s_{1,1}+s_{1,2}+s_{2,1}+s_{2,2}} & {s_{1,3}+s_{2,3}} &{s_{3,1}+s_{3,2}}
& {s_{3,3}} &
{0} & {0} & {0} & {0} & {0} \cr
{1} & {0} & {0} & {0} & {0} & {0} & {0} & {0} & {0} \end{matrix}} \right),
\end{align*}
for the case that the systems are working at time  $t$ with
 $j_1=1$ component failure (here,
 $s_{i_1,i_2}\ge 0$ with
 $1\le i_1,i_2\le 3$, and
 $\sum\nolimits_{i_1=1}^3\sum\nolimits_{i_2=1}^3 s_{i_1,i_2}=1$), the discrete-time dynamic joint signature can be given as
 \begin{align*}
{\boldsymbol{s}}_{1} =& \left( {\begin{matrix}
{s_{2,2}^{1|1,1}} & {s_{2,3}^{1|1,1}} & {s_{3,2}^{1|1,1}} & {s_{3,3}^{1|1,1}} \cr
{s_{2,2}^{1|2}} & {0} & {0} & {0} \end{matrix}} \right) \cr
=&\left( {\begin{matrix}
{s_{2,2}}\over{s_{2,2}+s_{2,3}+s_{3,2}+s_{3,3}} & {s_{2,3}}\over{s_{2,2}+s_{2,3}+s_{3,2}+s_{3,3}} & {s_{3,2}}\over{s_{2,2}+s_{2,3}+s_{3,2}+s_{3,3}} & {s_{3,3}}\over{s_{2,2}+s_{2,3}+s_{3,2}+s_{3,3}} \cr
1 & {0} & {0} & {0} \end{matrix}} \right) .
\end{align*}
The discrete-time joint signature  $\tilde{\boldsymbol{s}}_1$ of their equivalent systems of size 3 can be given in the same way, which means similar to Example 3.3, burn-in should be carried out if and only if
 \begin{align*}
\left(\begin{matrix}
s_{1,1}&s_{1,2}&s_{1,3}\cr
s_{2,1}&s_{2,2}&s_{2,3}\cr
s_{3,1}&s_{3,2}&s_{3,3}
\end{matrix}\right)&\le _{st}
\left(\begin{matrix}
{2\over 3}{s_{2,2}^{1|1,1}}& {1\over 3}{s_{2,3}^{1|1,1}} & {1\over 3}{s_{2,3}^{1|1,1}} \cr
{1\over 3}{s_{3,2}^{1|1,1}} & {1\over 3}{s_{2,2}^{1|1,1}}+{1\over 3}{s_{3,3}^{1|1,1}} & {1\over 3}{s_{2,3}^{1|1,1}} \cr
{1\over 3}{s_{3,2}^{1|1,1}} & {1\over 3}{s_{3,2}^{1|1,1}} & {2\over 3}{s_{3,3}^{1|1,1}}
\end{matrix}\right) \cr
&={{1}\over{3(s_{2,2}+s_{2,3}+s_{3,2}+s_{3,3})}} \cdot \left(\begin{matrix}
2s_{2,2}&s_{2,3}&s_{2,3}\cr
s_{3,2}&s_{2,2}+s_{3,3}&s_{2,3}\cr
s_{3,2}&s_{3,2}&2s_{3,3}
\end{matrix}\right).
\end{align*}
In practice, we are often interested in joint residual lifetime distributions of two working systems with shared components, given the number of failed components before/at the observation time. Now, let us turn to the study of conditional joint distribution of the systems given the  $(r+1,\ldots,r+N)$th component failure (
 $N\ge 1$) at time
 $x\ge 1$.
Theorem 3.1 Let  $\boldsymbol{s}$ be the discrete-time joint signature of two coherent systems with
 $n$ shared i.i.d. components as in Definition 3.1 such that
 $s_{i_1,i_2}^{j_1,\ldots,j_m}=0$ for all
 $j_1+\cdots+j_{i_1\wedge i_2} \lt l$. Then, the joint pmf of conditional residual system lifetimes
 $(T_1-x,T_2-x|X_{(r+1,\ldots,r+N):n}=x)$ for
 $1\le r+1 \lt \cdots \lt r+N \lt l$ and
 $x\ge 1$ can be given as
 \begin{align*}
&P(T_1-x=t_1,{{\rm ~}}T_2-x=t_2| X_{(r+1,\ldots,r+N):n}=x)\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i_1=1}^m \sum\limits_{i_2=1}^m s_{i_1,i_2}^{j_1,\ldots,j_m} \cdot P(X_{j_{(i_1-1)}+1:n}=x+t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=x+t_2,\cr
&E_{j_1,\ldots,j_m}| X_{(r+1,\ldots,r+N):n}=x),{{\rm ~~~~~}}t_1,t_2\ge 1 .
\end{align*}
Proof. The joint pmf of  $(T_1,T_2,X_{(r+1,\ldots,r+N)}:n)$ can be given as
 \begin{align*}
&P(T_1=t_1,{{\rm ~}}T_2=t_2,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x)\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i_1=1}^m\sum\limits_{i_2=1}^m P(T_1=t_1,{{\rm ~}}T_2=t_2,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x|T_1=X_{j_{(i_1-1)}+1:n},\cr
&T_2=X_{j_{(i_2-1)}+1:n},{{\rm ~}}E_{j_1,\ldots,j_m})\cdot P(T_1=X_{j_{(i_1-1)}+1:n},{{\rm ~}}T_2=X_{j_{(i_2-1)}+1:n},{{\rm ~}}E_{j_1,\ldots,j_m})\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i_1=1}^m\sum\limits_{i_2=1}^m P(X_{j_{(i_1-1)}+1:n}=t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=t_2,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x|T_1=X_{j_{(i_1-1)}+1:n},\cr
&T_2=X_{j_{(i_2-1)}+1:n},{{\rm ~}}E_{j_1,\ldots,j_m})\cdot P(T_1=X_{j_{(i_1-1)}+1:n},{{\rm ~}}T_2=X_{j_{(i_2-1)}+1:n}|E_{j_1,\ldots,j_m})P(E_{j_1,\ldots,j_m})\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i_1=1}^m\sum\limits_{i_2=1}^m P(X_{j_{(i_1-1)}+1:n}=t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=t_2,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x|E_{j_1,\ldots,j_m})\cr
&\cdot s_{i_1,i_2}^{j_1,\ldots,j_m}\cdot P(E_{j_1,\ldots,j_m})\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i_1=1}^m \sum\limits_{i_2=1}^m s_{i_1,i_2}^{j_1,\ldots,j_m} \cdot P(X_{j_{(i_1-1)}+1:n}=t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=t_2,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x,\cr
&E_{j_1,\ldots,j_m}),{{\rm ~~~~~}}t_1,t_2\ge x+1,
\end{align*}
which implies that the joint pmf of  $(T_1-x,{{\rm ~}}T_2-x|X_{(r+1,\ldots,r+N):n}=x)$ is given by
 \begin{align*}
&P(T_1-x=t_1,{{\rm ~}}T_2-x=t_2| X_{(r+1,\ldots,r+N):n}=x)\cr
=&{{P(T_1=x+t_1,{{\rm ~}} T_2=x+t_2,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x)}\over{P( X_{(r+1,\ldots,r+N):n}=x)}}\cr
=&\sum\limits_{m=1}^n\sum\limits_{j_1+\cdots+j_m=n}\sum\limits_{i_1=1}^m \sum\limits_{i_2=1}^m s_{i_1,i_2}^{j_1,\ldots,j_m} \cdot P(X_{j_{(i_1-1)}+1:n}=x+t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=x+t_2,\cr
&E_{j_1,\ldots,j_m}|X_{(r+1,\ldots,r+N):n}=x),{{\rm ~}}t_1,t_2\ge 1.
\end{align*}
Remark 3.6. Similar to Remark 2.6, we have
 \begin{equation*}P(X_{(r+1,\ldots,r+N):n}=x)={{n!}\over{r!N!(n-r-N)!}}\bar F^{r}(x-)f^N(x)F^{n-r-N}(x).\end{equation*}
With  $r=j_{(w)}$,
 $r+N=j_{(w+1)}$, the event
 \begin{align*}
&\{X_{j_{(i_1-1)}+1:n}=x+t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=x+t_2,{{\rm ~}}X_{(r+1,\ldots,r+N):n}=x,{{\rm ~}}E_{j_1,\ldots,j_m}\}\end{align*}
can be written as
 \begin{align*}
&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(w)}+1,\ldots,j_{(w+1)}):n}}=x \lt \cdots \lt {X_{(j_{(i-1)} +1,\ldots,j_{(i)} ):n}}=x+t\cr
& \lt \cdots \lt {X_{(j_{(m-1)} +1,\ldots,j_{(m)} ):n}}\}I_{\{i_1=i_2=i\}},{{\rm ~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~for~} t_1=t_2=t};
\cr
&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(w)}+1,\ldots,j_{(w+1)}):n}}=x \lt \cdots \lt {X_{(j_{(i_1-1)} +1,\ldots,j_{(i_1)} ):n}}=x+t_1\cr
& \lt \cdots \lt {X_{(j_{(i_2-1)} +1,\ldots,j_{(i_2)} ):n}}=x+t_2 \lt \cdots \lt {X_{(j_{(m-1)} +1,\ldots,j_{(m)} ):n}}\}I_{\{i_1 \lt i_2\}},{{\rm ~~~for~}} t_1 \lt t_2;\cr
&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(w)}+1,\ldots,j_{(w+1)}):n}}=x \lt \cdots \lt {X_{(j_{(i_2-1)} +1,\ldots,j_{(i_2)} ):n}}=x+t_2\cr
& \lt \cdots \lt {X_{(j_{(i_1-1)} +1,\ldots,j_{(i_1)} ):n}}=x+t_1 \lt \cdots \lt {X_{(j_{(m-1)} +1,\ldots,j_{(m)} ):n}}\}I_{\{i_1 \gt i_2\}},{{\rm ~~~for~}} t_1 \gt t_2.\\
\end{align*}
More generally, without the assumption that the systems can not fail with less than  $l$ component failures, the above residual system lifetimes can be considered as follows.
Theorem 3.2 Let  $\boldsymbol{s}_{j_1,\ldots,j_k}$ be the discrete-time dynamic joint signature of two coherent systems with
 $n$ shared i.i.d. components as in Definition 3.2. If
 $P(E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T_1 \gt x,{{\rm ~}}T_2 \gt x) \gt 0$, the joint pmf of conditional residual system lifetimes
 $(T_1-x,{{\rm ~}}T_2-x|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T_1 \gt x,{{\rm ~}}T_2 \gt x)$ for
 $x,t_1,t_2\ge 1$ can be given as
 \begin{align*}
&P(T_1-x=t_1,{{\rm ~}}T_2-x=t_2|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T_1 \gt x,{{\rm ~}}T_2 \gt x)\cr
=&\sum\limits_{i_1=k+1}^m\sum\limits_{i_2=k+1}^m {s_{i_1,i_2}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}} P(X_{j_{(i_1-1)}+1:n}=x+t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=x+t_2|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m}).
\end{align*}
Proof. The pmf of  $(T_1-x,{{\rm ~}}T_2-x|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T \gt x)$ can be given as
 \begin{align*}
&P(T_1-x=t_1,{{\rm ~}}T_2-x=t_2|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T_1 \gt x,{{\rm ~}}T_2 \gt x)\cr
=&\sum\limits_{i_1=1}^m\sum\limits_{i_2=1}^m P(T_1=X_{j_{(i_1-1)}+1:n},{{\rm ~}}T_2=X_{j_{(i_2-1)}+1:n}|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T_1 \gt x,{{\rm ~}}T_2 \gt x)P(T_1=x+t_1,\cr
& T_2=x+t_2|T_1=X_{j_{(i_1-1)}+1:n},{{\rm ~}}T_2=X_{j_{(i_2-1)}+1:n},{{\rm ~}}E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T_1 \gt x,{{\rm ~}}T_2 \gt x)\end{align*}
 \begin{align*}
=&\sum\limits_{i_1=1}^m\sum\limits_{i_2=1}^m P(T_1=X_{j_{(i_1-1)}+1:n},{{\rm ~}}T_2=X_{j_{(i_2-1)}+1:n}|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T_1 \gt x,{{\rm ~}}T_2 \gt x)P(X_{j_{(i_1-1)}+1:n}\cr
& =x+t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=x+t_2|T_1=X_{j_{(i_1-1)}+1:n} \gt x,{{\rm ~}}T_2=X_{j_{(i_2-1)}+1:n} \gt x,{{\rm ~}}E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m})\cr
=&\sum\limits_{i_1=k+1}^m\sum\limits_{i_2=k+1}^m P(T_1=X_{j_{(i_1-1)}+1:n},{{\rm ~}}T_2=X_{j_{(i_2-1)}+1:n}|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m},{{\rm ~}}T_1 \gt x,{{\rm ~}}T_2 \gt x)\cr
&\times P(X_{j_{(i_1-1)}+1:n}=x+t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=x+t_2|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m})
\cr
=&\sum\limits_{i_1=k+1}^m\sum\limits_{i_2=k+1}^m {s_{i_1,i_2}^{j_1,\ldots,j_{k}|j_{k+1},\ldots,j_{m}}} P(X_{j_{(i_1-1)}+1:n}=x+t_1,{{\rm ~}}X_{j_{(i_2-1)}+1:n}=x+t_2|E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m}).
\end{align*}
Remark 3.7. Note that with event  $E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m}$ as defined in Remark 2.1, the event
 \begin{align*}
&\{X_{j_{(i_1-1)}+1:n}=x+t_1, {{\rm ~}}X_{j_{(i_2-1)}+1:n}=x+t_2, {{\rm ~}}E_{j_1,\ldots,j_k,x,j_{k+1},\ldots,j_m}\}
\end{align*}
can be written as
 \begin{align*}
&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(k-1)}+1,\ldots,j_{(k)}):n}}\le x \lt X_{(j_{(k)}+1,\ldots,j_{(k+1)}):n} \lt \cdots \lt {X_{(j_{(i-1)}+1,\ldots,j_{(i)}):n}}=
\cr
&x+t \lt \cdots \lt {X_{(j_{(m-1)}+1,\ldots,j_{(m)}):n}}\}I_{\{i_1=i_2=i\}},{{\rm ~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~for~}}t_1=t_2=t;
\cr
&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(k-1)}+1,\ldots,j_{(k)}):n}}\le x \lt X_{(j_{(k)}+1,\ldots,j_{(k+1)}):n} \lt \cdots \lt {X_{(j_{(i_1-1)}+1,\ldots,j_{(i_1)}):n}}=
\cr
&x+t_1 \lt \cdots \lt {X_{(j_{(i_2-1)}+1,\ldots,j_{(i_2)}):n}}=x+t_2 \lt \cdots \lt {X_{(j_{(m-1)}+1,\ldots,j_{(m)}):n}}\}I_{\{i_1 \lt i_2\}},{{\rm ~~~~~for~}}t_1 \lt t_2;
\cr
&\{X_{(1,\ldots,j_{(1)}):n} \lt \cdots \lt {X_{(j_{(k-1)}+1,\ldots,j_{(k)}):n}}\le x \lt X_{(j_{(k)}+1,\ldots,j_{(k+1)}):n} \lt \cdots \lt {X_{(j_{(i_2-1)}+1,\ldots,j_{(i_2)}):n}}=
\cr
&x+t_2 \lt \cdots \lt {X_{(j_{(i_1-1)}+1,\ldots,j_{(i_1)}):n}}=x+t_1 \lt \cdots \lt {X_{(j_{(m-1)}+1,\ldots,j_{(m)}):n}}\}I_{\{i_1 \gt i_2\}},{{\rm ~~~~~for~}}t_1 \gt t_2.
\end{align*}
4. Concluding remarks
In this work, we generalize the dynamic signature proposed by Samaniego et al. [Reference Samaniego, Balakrishnan and Navarro18] and the residual signature proposed by Lindqvist and Samaniego [Reference Lindqvist and Samaniego12] to the discrete-time case. Associated properties of the discrete-time dynamic signature are discussed in detail, including its relationship with the discrete-time residual signature. Related discussions are also generalized to two coherent systems with shared components by proposing the concepts of discrete-time dynamic joint signature and discrete-time residual joint signature. Related applications can be found in practical reliability systems such as communication network systems, smart street light systems, unmanned aerial vehicle systems, hardware load balancer group systems, and so on. The present work can be generalized to multi-state coherent systems and then study their structural properties under the discrete-time setup. We are currently working on this problem and hope to report the findings in a future paper.
Acknowledgments
This work was supported by the Beijing Natural Science Foundation (No. 9242011), the China Scholarship Council, the Fundamental Research Funds for the Central Universities (buctrc202102), and the Natural Sciences and Engineering Research Council of Canada (to the second author) through an Individual Discovery Grant (RGPIN-2020-06733). The authors express their sincere thanks to the Associate Editor and the anonymous reviewers for all their useful comments and suggestions on an earlier version of this manuscript, which resulted in this improved version.


 Open access

