


In the “additive transformation” model of relations proposed by Leech et al., a relation R holding between two objects, Object 1 and Object 2, is represented by a transformation vector T, which, when added to the feature vector representing Object 1, produces the feature vector representing Object 2. The transformation vector T defines the relation R: if any pair of objects are related by relation R, that means the first object can be transformed into the second object by adding the vector T; conversely, if one object can be transformed into another object by adding the vector T, that means those two objects can stand in relation R to each other. (The zero vector has a special meaning in this model: it represents the auto-association relation, which simply transforms an object into itself.) Leech et al. use this transformational representation of relations to simulate and test a relational priming account of analogy. These simulations involve training a connectionist network to learn relations encoded as transformations. To train the network on relation R the network is presented with pairs of objects in which the first object's feature vector differs from the second by the transformation vector T. These object pairs are presented in conjunction with a feature vector that labels the relation in some way. Over the course of training, the network learns to associate the relation label with the transformation required to get from one object in a pair to the other; in other words, the network learns the transformation. Leech et al. show that networks trained in this way can learn a number of different relations and can, by allowing objects to prime relations, carry out simulations of something very like analogical reasoning. These simulations produce results that agree with those seen in experimental studies of analogy, and thus support a relational priming model of analogy.
Although this additive transformation model is plausible for causal relations such as the cutting relation used by Leech et al., in general relations cannot be represented by transformations. The problem is that many relations are bidirectional: they can hold both between Object 1 and Object 2 and also between Object 2 and Object 1. The relation threatens, for example (which Leech et al. also use in their simulations), is bidirectional: it can hold both between Iraq and the United States (i.e., Iraq threatens the United States) and between the United States and Iraq (i.e., the United States threatens Iraq). Both directions of a bidirectional relation, however, cannot be represented via the same additive transformation, and so such relations cannot be represented in an additive transformation model of relations.
To see why bidirectional relations cannot be represented in the additive transformation model proposed by Leech et al., assume that relation R is bidirectional and that R holds both between Object 1 and Object 2 and between Object 2 and Object 1. Let [Object 1] represent the feature vector describing Object 1, and [Object 2] denote that describing Object 2. By definition, for the relation R to hold in both directions, the two expressions
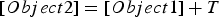
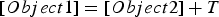
must both be true (where T is the transformational vector representing relation R, as before). However, by substituting Equation 1 into Equation 2 we can see that this means
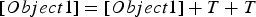
must be true. This can only be true when

Thus the bidirectional relation between two objects can only be represented via transformation if the transformational vector T applied to convert one object to the other is simply the zero vector. But the zero vector only “converts” one object into itself (auto-association, in Leech et al.'s terms). The additive transformation model is thus unable to represent bidirectional relations between two different objects. This means that if a transformational system of relations is set up to represent “Iraq threatens the United States,” that system is necessarily unable to represent “the United States threatens Iraq.”
Leech et al.'s additive transformation model of relations, then, can only apply to relations which are not bidirectional: relations which, if they hold between Object 1 and Object 2, cannot hold between Object 2 and Object 1. The causal relations used by Leech et al. in their first simulation are clearly not bidirectional because they involve irreversible physical change to an object: the cutting relation transforms an apple into a cut apple, but cannot transform a cut apple back into an apple. Leech et al. have thus provided a relational priming model of analogy which works for certain types of relations (relations that are not bidirectional), but not for relations in general.
This difficulty with bidirectional relations does not take away from the success of Leech et al.'s account of analogy as relational priming. Their account applies well to an important, and perhaps a fundamental, type of relation (simple causal relations), and gives a good account for the developmental results on analogies using relations of that type (Goswami & BrownReference Goswami and Brown1989; Goswami et al. Reference Goswami, Leevers, Pressley and Wheelwright1998). It may be possible to extend this account by using a different transformational model of relations rather than the additive model used by Leech et al. – for example, a transformational model based on modular arithmetic may be able to successfully represent bidirectional relations. It is hard to see how modular arithmetic could be implemented in a connectionist network, however. It may be better to accept that the transformational model of relations will only work well for relations that actually involve transformations: for relations that are not transformations, a different model will be needed.
ACKNOWLEDGMENT
The author was supported by the FP6 NEST Programme of the European Commission (ANALOGY: Humans – the Analogy-Making Species: STREP Contr. No 029088).


