1. INTRODUCTION
Integration between the Global Positioning System (GPS) and Inertial Navigation Systems (INS) can be used for providing navigation information (position, velocity and attitude) (Chu et al., Reference Chu, Tsai, Chiang and Duong2013). This has been investigated for several years in different applications, such as military, agricultural and so on. In the integrated navigation system, the GPS provides highly accurate position and velocity information over long periods, while the INS provides accurate attitude information in the short term. When a GPS receiver is used to obtain position, it needs to receive the satellite signal. In contrast, an INS is a self-contained device for velocity and attitude data. It is clear that integrating GPS and INS can deliver an enhanced performance over the individual systems (Nassar, Reference Nassar2003).
GPS information can be used to correct the INS error in GPS/INS integrated navigation. When the integrated navigation systems enter a tunnel or canyon, degraded navigation solutions are yielded in the absence of GPS since the INS navigation precision degrades rapidly with time if no external aiding source is available (Georgy et al., Reference Georgy, Karamat, Iqbal and Noureldin2011). When the GPS signal is lost, another sensor with no need of external aiding can be applied to integrate with INS. The speed of a vehicle obtained from the odometer has the same property as GPS observation. In order to enhance the performance of GPS/INS integration during GPS outages the odometer observation is used as a measurement to update the state vector of a Kalman filter. The odometer produces more frequent velocity measurement than the GPS and it is also self-contained and hardly disturbed. The lever arm is an important effect in a GPS/INS/odometer integrated system, so a compensation method considering the influence of the scale factor error and the coordinate transformation errors of an odometer was applied to the GPS/INS/odometer integrated system and improved navigation precision (Seo et al., Reference Seo, Lee, Lee and Park2006). By changing the output signal which drives the filter, the lever arm correction was performed and the odometer bias was also estimated in real time (Hemerly and Schad, Reference Hemerly and Schad2008). Because more sensors joined in the integrated system, more filters were proposed. The performance of the two-dimensional (2-D) navigation solution by integrating a GPS receiver, a Micro-Electro-Mechanical System (MEMS) gyroscope and an odometer using a Mixture Particle Filter (PF) once with the parallel cascade identification model and once with the autoregressive stochastic model was tested in a land vehicle (Georgy et al., Reference Georgy, Noureldin, Korenberg and Bayoumi2010). Although the odometer can obtain the velocity during a GPS outage, the precision of the odometer velocity is worse than GPS. At the same time, the odometer can only derive the speed value in the direction of vehicle motion. In the INS/odometer integrated system, the velocity in NED (north, east and down) frame will be calculated by use of pitch and roll calculated from the INS system together with the odometer data. It can be shown that the accuracies of the odometer and INS restrain each other. So the INS/odometer integrated system cannot keep a high accuracy navigation solution over long GPS outages.
A structure of neural network predictions was constructed to offer more precise resolution when a GPS outage is encountered (Kaygisiz et al., Reference Kaygisiz, Erkmen and Erkmen2004). An intelligent position and attitude determination system aided by an artificial neural network (ANN) with conventional Rauch-Tung-Striebel (RTS) smoother was proposed to increase the overall accuracy of a GPS/INS integrated system in post-processing mode by Chiang et al. (Reference Chiang, Chang, Li and Huang2009). The main work of Kaygisiz et al. (Reference Kaygisiz, Erkmen and Erkmen2007) in ANN applied to a GPS/INS integrated system focused on the construction, implementation and integration of an ANN using an optimum multilayer perceptron structure with relevant number of layers and a suitable learning method. Considering that the error in the past data of INS is dependent, a GPS/INS integration system aided by an Input-Delay Neural Network was presented to predict the INS error and give reliable error estimates of INS position and velocity observation (Noureldin et al., Reference Noureldin, El-Shafie and Bayoumi2011). A window-based weights updating scheme was given to accumulate navigation knowledge, which can provide alternative weight updating algorithms for GPS/INS integration and can increase the position accuracy in GPS outages (Chiang, Reference Chiang2004). The ANN method makes use of the inner relationship in a GPS/INS integrated system. Without the other sensors, this method is ideal. At the same time, the relationship used by ANN is not tight, because the GPS and INS are independent systems, especially in loose coupled navigation, and the raw observation from INS and GPS is different. The reliability of the method using an artificial neural network is low over long GPS outages.
In the present study, a GPS/INS/odometer integrated system aided by fuzzy neural network is proposed to obtain higher accuracy navigation information over long GPS outages. The objective of this study is to improve the integrated navigation system precision during long GPS outages. The topology of an FNN is constructed based on the measurement type of the GPS and odometer being the same. The information from GPS, odometer and IMU is input into the FNN system for network training during signal availability, while the FNN model receives the observation from IMU and odometer to generate the odometer velocity correction to enhance velocity accuracy over long GPS outages. The paper is divided into 5 sections. Following this introduction, the dynamic model and observation model in GPS/INS/odometer integrated navigation is overviewed in Section 2. Section 3 describes the conventional GPS/INS/odometer integrated system, including the structure and data stream. Section 4 reveals the fuzzy neural network and the proposed integrated system. Results are then presented and analysed in Section 5, followed by a summary of the main conclusions.
2. GPS/INS/ODOMETER INTEGRATED NAVIGATION MODEL
2.1. Dynamics Model
The system error dynamic model of integrated navigation used in the Kalman filter is designed based on the INS error equations. The insignificant terms are neglected in the process of linearization (Titterton, Reference Titterton2004). The psi-angle error equations of INS are as follows (Han and Wang, Reference Han and Wang2012):
 $$\delta {\bi \dot r} = - {\bi \omega} _{en} \times \delta {\bi r} + \delta {\bi v}$$
 $$\delta {\bi \dot v} = - (2{\bi \omega} _{ie} + {\bi \omega} _{en} ) \times \delta {\bi v} - \delta {\bi \psi} \times {\bi f} + {\bi \delta} $$
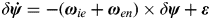 $$\delta {\bi \dot \psi} = - ({\bi \omega} _{ie} + {\bi \omega} _{en} ) \times \delta {\bi \psi} + {\bi \varepsilon} $$
where δ r, δ v and δψ are the position, velocity and orientation error vectors, respectively. ωen is the rate of navigation frame with respect to earth, and ωie is the rate of earth with respect to inertial frame. The system error dynamics of GPS/INS integration is obtained by expanding the accelerometer bias error vector η and the gyro drift error vector ε.
The accelerometer bias error vector η and the gyro drift error vector ε are regarded as the random walk process vectors, which are modelled as follows (Wang et al., Reference Wang, Lee, Hewitson and Lee2003):
 $${\bi \dot \eta} = {\bi u}_\eta $$
 $${\bi \dot \varepsilon} = {\bi u}_\varepsilon $$
where uη and uε are white Gaussian noise vectors.
By combining Equations (1) to (5), the system dynamical model becomes:
 $$\left\{ \matrix{\delta {\bi \dot r} = - {\bi \omega} _{en} \times \delta {\bi r} + \delta {\bi v} \cr \delta {\bi \dot v} = - ({\bi \omega} _{ie} + {\bi \omega} _{in} ) \times \delta {\bi v} - \delta {\bi \psi} \times {\bi f} + {\bi \eta} \cr \delta {\bi \dot \psi} = - {\bi \omega} _{in} \times \delta {\bi \psi} + {\bi \varepsilon} \cr {\bi \eta} = {\bi u}_\eta \cr {\bi \varepsilon} = {\bi u}_\varepsilon } \right.$$
which can be generalized in matrix and vector form:
 $${\bi \dot X} = {\bi \Phi X} + {\bi u}$$
wherein X is the error state vector, Φ is the system transition matrix, and u is the process noise vector.
2.2. GPS/INS Observation Model
The observation model in GPS/INS integrated navigation is composed of the position and velocity difference vector between the GPS solutions and the INS computation value:
 $$\eqalign{Z_r (t) = & r_{GPS} (t) - r_{INS} (t) \cr = & r_{GPS} (t) - \left( {r_{INS} (t - \Delta t) + v_{INS} (t - \Delta t) \cdot \Delta t + \displaystyle{1 \over 2}\alpha (t) \cdot \Delta t^2} \right)} $$
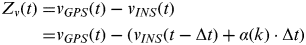 $$\eqalign{Z_v (t) = & v_{GPS} (t) - v_{INS} (t) \cr = & v_{GPS} (t) - (v_{INS} (t - \Delta t) + \alpha (k) \cdot \Delta t)} $$
where Z r(t) is the position error measurement vector at t time, Z v(t) is the velocity error measurement vector, r GPS(t) is the GPS position vector, r INS(t) is the INS position vector, v GPS(t) is the GPS velocity vector, v INS(t) is the INS velocity vector, α(t) is the acceleration vector determined by the INS alone, and Δt is the sample time of IMU.
The generic measurement equation system of the Kalman filter can be written as:
 $${\bi Z}_k = \left[ {\matrix{ {Z_r (t)} \cr {Z_v (t)} \cr}} \right] = {\bi B}_k \left[ {\matrix{ {{\bi X}_{Nav}} \cr {{\bi X}_{Acc}} \cr {{\bi X}_{Gyo}} \cr}} \right] + \left[ {\matrix{ {\tau _r} \cr {\tau _v} \cr}} \right]$$
where Bk is the observation matrix, and τ is the measurement noise vector, assumed to be white Gaussian noise.
2.3. INS/odometer Observation Model
2.3.1. Odometer Position and Velocity
An odometer can only measure the overall velocity of the vehicle. Suppose the vehicle velocity output by odometer is v O and its direction is the same as the front of the vehicle. The velocity of the vehicle observed by odometer can be written in the navigation frame (Yan, Reference Yan2006):
 $${\bi v}_O^n = {\bi C}_b^n \left[ {\matrix{ 0 & {v_O} & 0 \cr}} \right]^T $$
where Cbn is the direction cosine matrix which defines the attitude of the body frame with respect to the navigation frame. In INS/odometer integrated navigation, Cbn can be obtained by INS computation.
The integration of velocity in the navigation frame is the position of the vehicle. The differential equation of position is expressed as:
 $$\dot L_O = \displaystyle{{v_{ON}^n} \over {R_M + h_O}} $$
 $$\dot \lambda _O = \displaystyle{{v_{OE}^n} \over {(R_N + h_O )\cos L_O}} $$
 $$\dot h_O = - v_{OD}^n $$
where L O, λO and h O are the longitude, latitude and height information calculated by INS/odometer integration system respectively. R M and R N are meridian and traverse radii of curvature in the earth ellipsoid. v nON, vOEn and v ODn are the velocity component of north, east and down directions in the local level navigation frame.
Because the position and velocity information of the odometer are sampled discretely, the computing method of the odometer position can be deduced based on the differential equation of position:
 $$L_O (k) = L_O (k - 1) + \displaystyle{{v_{ON}^n \cdot \Delta t} \over {R_M + h}}$$
 $$\lambda _O (k) = \lambda _O (k - 1) + \displaystyle{{v_{OE}^n \cdot \Delta t} \over {(R_N + h)\cos L_O (k - 1)}}$$
 $$h_O (k) = h_O (k - 1) - v_{OD}^n \cdot \Delta t$$
where (k−1) is the k−1 time of the odometer position, (k) is the k time of the odometer position, and Δt is the sample interval of the odometer.
2.3.2. INS/odometer Observation Model
The INS/odometer observation model is similar to the GPS/INS observation model. The position difference between the odometer and INS which is transformed from geodetic coordinate system to navigation frame, with the velocity difference, is the observation input of the Kalman filter. Because the ability of the odometer to sensor the velocity in the down direction is weak (Yan, Reference Yan2006), so in the INS/odometer integrated system, the observation input of the Kalman filter only includes the measurement in the north and east directions:
 $${\bi Z}_k^O = \left[ {\matrix{ {\Delta r_N} \cr {\Delta r_E} \cr {\Delta v_N} \cr {\Delta v_N} \cr}} \right] = {\bi B}_k^O \left[ {\matrix{ {{\bi X}_{Nav}} \cr {{\bi X}_{Acc}} \cr {{\bi X}_{Gyo}} \cr}} \right] + \left[ {\matrix{ {\nu _r} \cr {\nu _v} \cr}} \right]$$
where BkO is the observation matrix of INS/odometer observation model.
2.4. Kalman Filter
The optimal estimates of the state vector from the Kalman filter can be reached through a time update and a measurement update at a time instant:
 $${\bi \hat X}_k = {\bi \hat X}_{k,k - 1} + {\bi K}_k ({\bi Z}_k - {\bi {\bi B}}_k {\bi \hat X}_{k,k - 1} )$$
 $${\bi K}_k = {\bi P}_{k,k - 1} {\bi B}_k^T ({\bi B}_k {\bi P}_{k,k - 1} {\bi B}_k^T + {\bi R}_k )^{ - 1} $$
 $${\bi \hat X}_{k,k - 1} = {\bi \Phi} _{k,k - 1} {\bi \hat X}_{k - 1} $$
 $${\bi P}_{k,k - 1} = {\bi \Phi} _k {\bi P}_{k - 1} {\bi \Phi} _k^T + {\bi Q}_k $$
 $${\bi P}_k = ({\bi I} - {\bi K}_k {\bi B}_k ){\bi P}_{k,k - 1} $$
In a closed loop integration scheme, a feedback loop is used for correcting the systematic errors. In this way, the mechanization performs simple navigation calculation under the assumption of small errors. In this case, the error states will be reset to zero after every measurement update (Godha, Reference Godha2006). Thus, the navigation resolution is expressed by:
 $${\bi \hat X}_k = {\bi P}_{k,k - 1} {\bi B}_k^T ({\bi B}_k {\bi P}_{k,k - 1} {\bi B}_k^T + {\bi R}_k )^{ - 1} {\bi Z}_k $$
3. GPS/INS/ODOMETER INTEGRATED NAVIGATION SYSTEM
In GPS/INS integrated navigation, the INS error will be corrected using the difference between GPS and INS solutions as the Kalman filter input. When the GPS measurement is unavailable, such as in a tunnel, an INS mechanization algorithm by itself will make the position and velocity diverge quickly. Based on GPS/INS integrated navigation, the other sensors can be introduced to solve this problem. Unlike GPS, the odometer is able to acquire the velocity information without an auxiliary signal. When the vehicle travels in the tunnel, the GPS signal is lost but the odometer can still make observations. A GPS/INS/odometer integrated navigation system can thus realize indoor and outdoor positioning. Figure 1 shows a loosely coupled GPS/INS/odometer integration structure with closed loop. It is important to note that the odometer measurement is input to the integrated system during GPS signal availability. Although the odometer velocity measurement accuracy is worse than GPS measurement, the odometer measurement is still able to play the role of gross error detector (Yan, Reference Yan2006).
A loosely coupled GPS/INS/odometer integration architecture.

4. GPS/INS/ODOMETER INTEGRATED SYSTEM USING FNN
4.1. Fuzzy Neural Network
In the study, a FNN scheme is proposed to learn and compensate for the odometer observation error and to improve the odometer observation accuracy during GPS outages. The T-S fuzzy system is a self-adaptive fuzzy system (Hsiao et al., Reference Hsiao, Chen, Liang, Xu and Chiang2005). The T-S model not only updates by itself, but also corrects the membership function of the fuzzy subset continually. This T-S fuzzy system is described by fuzzy IF-THEN rules:
 $${\rm if}\;{\rm} x_1 \;{\rm is}\;A_1^i, x_2 \;{\rm is}\;A_2^i, {\rm \ldots}, x_k \;{\rm is}\;A_k^i \;{\rm then}\;y_i = p_0^i + p_1^i x_1 + \cdots + p_k^i x_k $$
where A ji(j=1,2, … k) is the fuzzy set of the fuzzy system, p ji is the fuzzy system parameters, y i is the output by fuzzy rule. In a fuzzy system, the input part is fuzzy; otherwise, the output is definite.
Suppose the input is x=[x 1,x 2, … x k]. At first, the membership of the input is computed according to the fuzzy rule:
 $$u_{A_j^i} = \exp ( - (x_j - c_j^i )^2 /b_j^i )\quad j = 1,2, \cdots, k;i = 1,2, \cdots, n$$
where c ji and b ji are the centre and width of membership function respectively, k is the number of input parameters, n is the number of fuzzy subsets. Gaussian membership functions provide more continuous transition from one interval to another and hence provide a smoother control surface from the fuzzy rules. At the same time, they are able to provide a system with fewer degrees of freedom and hence more robustness. Thus, Gaussian membership functions are suitable for problems which require continuously differentiable curves and therefore smooth transitions, whereas the others (such as triangular) do not posses these abilities (Hameed, Reference Hameed2011).
The fuzzy factor is computed by membership value using the continuous multiplication:
 $$\omega ^i = \prod\limits_{g = 1}^k {u_{A_j^g} (x_g )\quad i = 1,2, \cdots, n} $$
Then the output y of the fuzzy model can be shown:
 $$y_i = {{\sum\limits_{i = 1}^n {\omega ^i \left( {\,p_0^i + p_1^i x_1 + \cdots + p_k^i x_k} \right)}} \Big / {\sum\limits_{i = 1}^n {\omega ^i}}} $$
A fuzzy neural network is composed of three layers, which are the input (pre-processing), hidden, and output (post-processing) layers. The hidden layers are composed of the fuzzy layer and the fuzzy rule calculation layer. The input value is fuzzy-processed to get the membership value by Equation (26) in the fuzzy layer. The fuzzy factor will be computed in the fuzzy rule calculation layer by Equation (27).
The training algorithm of fuzzy neural network is as follows (Wang et al., Reference Wang, Shi, Yu and Li2012):
(1) Calculate error:
(29)where y d is the exception output of neural network, y c is the real output of neural network, e is the error between exception output and real output. $$e = \displaystyle{1 \over 2}(y_d - y_c )^2 $$
(2) Modify coefficient
(30)$$p_j^i (k) = p_j^i (k - 1) - \alpha \displaystyle{{\partial e} \over {\partial p_j^i}} $$(31)where α is the neural network training rate.$$\displaystyle{{\partial e} \over {\partial p_j^i}} = {{(y_d - y_c )\omega ^i} \Big/ {\sum\limits_{i = 1}^n {\omega ^i x_j}}} $$(3) Modify parameters
(32)$$c_j^i (k) = c_j^i (k - 1) - \alpha \displaystyle{{\partial e} \over {\partial c_j^i}} $$(33)$$b_j^i (k) = b_j^i (k - 1) - \alpha \displaystyle{{\partial e} \over {\partial b_j^i}} $$


The topological structure of an FNN is designed from small processing units (neurons) that are connected within the network using weighted chains. Generally speaking, the basic model of the neural network includes three primary elements: (a) weight chains, (b) a calculator for summing the input data that are weighted by respective synapses of the neuron; and (c) an activation function for restricting the amplitude of the neural network output and the last output (Chiang et al., Reference Chiang, Chang, Li and Huang2009).
4.2. GPS/INS/Odometer Integrated System Using Fuzzy Neural Network
A detailed block diagram of the proposed fuzzy neural network is shown in Figure 2. In order to progress the implementation of the FNN, a number of parameters should be set. These contain the training threshold contribution, the training momentum, the training rate and the number of hidden layers to be used (Petropoulos et al., Reference Petropoulos, Vadrevu, Xanthopoulos, Karantounias and Scholze2010). An ANN with an optimal structure is expected to realize the closest accuracy to the prediction model using the most suitable number of hidden neurons and hidden layers. There are many ways to decide on the most suitable number of hidden neurons, such as genetic algorithms (Kuo et al., Reference Kuo, Chen and Hwang2001), which is applied in this paper.
Three layer neural network of proposed integrated system.
A genetic algorithm (GA) process requires three most important aspects: (1) the genetic representation of the solution domain, (2) the genetic operators of the solution domain and (3) an objective function to evaluate the solution domain. Steps of a general GA process are as follows:
(1) Initial: generate initial parent population and define the crossover and mutation probability;
(2) Selection: evaluate the objective function and select chromosomes for reproduction;
(3) Crossover and Mutation: create offspring using reproduction operators such as crossover and mutation;
(4) Termination: repeat the generational process until a termination condition has been reached.
The construction of objective function is key to the GA process. In the FNN of our GPS/INS/odometer integrated system, the velocity difference between the odometer and GPS is the output. Based on this, the objective function used in the GA to choose the FNN parameters is constructed as:
 $$\varphi (\lambda ) = (\delta v'_{ON} - \delta v_{ON} )^2 + (\delta v'_{OE} - \delta v_{OE} )^2 $$
where λ are the FNN parameters (number of hidden neurons), δv ON and δv OE are the difference between GPS and odometer (odometer velocity correction) in north and east directions, δv′ ON and δv′ OE are the difference velocity predicted by FNN. When the function φ trends to zero, the most appropriate parameters will be chosen.
As is well known, one important component of the FNN is to acquire the training data which are required to train the neurons to accurately estimate the system (Chiang and Chang, Reference Chiang and Chang2010). In the FNN of our GPS/INS/odometer integrated system, the training phase records the IMU observation and odometer observation in the NED frame as the input. The output, velocity difference between the odometer and GPS, is a 2-D vector with north velocity and east velocity as components. The odometer is only able to sense the displacement in a plane, so it is difficult to record the three-dimensional motion. In land navigation applications, the vehicle always remains on the Earth's surface, so the vehicle positions have no large changes in the vertical direction (Han and Wang, Reference Han and Wang2010). It is reasonable to assume that the vehicle moves in an approximately horizontal plane in most cases. Thus the ability of the odometer to sense the velocity in the down direction is weak (Yan, Reference Yan2006), so the output of the FNN excludes it. The reason for using the velocity differences instead of the velocity component itself as output is to simplify the learning and training process.
Figure 3 illustrates the FNN system configuration and training strategy. During the training phase, the velocity difference between GPS and the odometer is selected as the target for the network training during signal availability. Thus the navigation knowledge can be learnt, stored and accumulated (Wang et al., Reference Wang, Wang, Sinclair and Watts2006). On the other hand, if the GPS signal is unavailable and the network is well trained, the proposed FNN model receives the acceleration and rotation rates from INS and velocity from the odometer to generate the velocity difference between GPS and the odometer (odometer velocity correction). Based on that, the estimate velocity can be computed by summing the odometer velocity and FNN output during GPS outages. IMU data participates in the INS computation and FNN process. The weight of IMU data in FNN prediction is low so the possibility of causing divergence of the navigation solutions is limited by double counting of INS computation and FNN prediction.
FNN training architecture of proposed integrated system.
Figure 4 shows a loosely coupled GPS/INS/odometer integration structure with closed loop using fuzzy neural network, which is proposed in this paper. The observation input of the Kalman filter is changed to the odometer measurement corrected by FNN in a GPS outage.
A proposed loosely coupled GPS/INS/odometer integration architecture.
5. RESULTS AND DISCUSSION
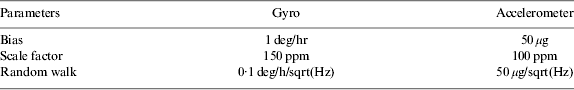
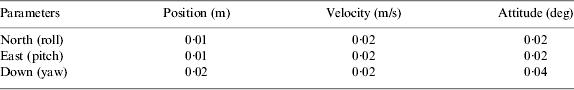
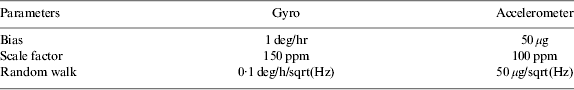
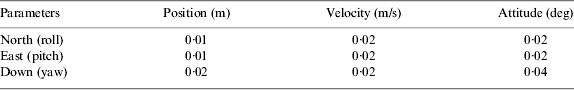
Field tests were conducted to evaluate the performance of the proposed method. The test system comprised two Leica GPS receivers, one non-touch vehicle speed sensor (odometer) and one navigation grade IMU. Raw IMU data, GPS data and odometer data were collected throughout the test navigation. One of the Leica receivers was set up as a reference station and the other one was used as a roving receiver with its antenna above the roof of the test vehicle. 1 Hz GPS data, 10 Hz odometer data and 100 Hz INS data were received and stored in a book computer. The period of the test was about 30 minutes. The GPS observation was processed using the GPS software GrafNav™ 8·0 in DGPS mode and the solution was regarded as the position and velocity reference. The attitude reference was generated by the DGPS/INS integrated system, which promises much better accuracy than the proposed GPS/INS/odometer integrated system using a single GPS receiver. The specifications of the IMU are given in Table 1. The reference solution accuracy in these conditions is summarised in Table 2. The IMU measurement was processed in the GPS/INS/odometer integrated system proposed in the paper for further analysis. Over the whole trajectory, no natural GPS outage was detected. After 1200 s, a simulated GPS outage was generated by removing the GPS observation.
Navigation grade IMU technical data.
Reference solution accuracy.
The GPS observations from 1 s to 1200 s were applied to train the FNN model. Figure 5 depicts the training results of two parameters (odometer velocity correction in north and east directions). FNN represents the modified odometer velocity by FNN estimate correction in Figure 5. The velocity of FNN has indicated closer to reference value mode than the velocity of odometer in north direction and east directions.
The training results of FNN: (a) velocity in north; (b) velocity error in north; (c) velocity in east; (d) velocity error in east.
Shown in Figure 5 are north and east velocity errors from odometer and FNN compared to the reference. It is noticed that the error of FNN velocity is smaller than odometer velocity. Training results show that the FNN model has good enough performance to estimate the odometer observation error.
After 1200 s, we applied the proposed FNN model to predict the odometer measurement error. Figure 6 provides the prediction results. As in the training phase, the velocity of FNN is closer to the reference value than the velocity of odometer in the north and east directions.
The prediction results of FNN: (a) velocity in north; (b) velocity error in north; (c) velocity in east; (d) velocity error in east.
Figure 6 shows north and east velocity errors from the odometer and FNN compared to the reference value. It can be seen that the error of FNN velocity is smaller than the odometer velocity error. The proposed FNN schemes learn the error behaviour of the odometer well during a simulated GPS outage.
The comparison trajectory is shown in Figure 7. From point 1 to point 2, no natural GPS outage was detected and the trajectory from point 2 to point 3 is during simulated GPS outage. The red line represents the reference from DGPS results, the yellow line represents the solution by the scheme of Figure 1 (scheme 1) and the blue line represents the solution of scheme proposed in the paper (scheme 2). The results show that scheme 1 exhibits low accuracy. The position error of scheme 1 gradually increases over time. At point 3, the position of scheme 1 deviates seriously from the highway. Scheme 2 mitigates the errors and improves the navigation result. The trajectory of scheme 2 is still located on the highway in the whole experiment process.
Comparison of the different schemes' trajectories.
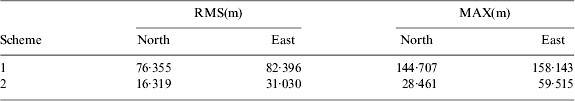
Position errors were computed with respect to the reference position to evaluate the performance. Table 3 illustrates root mean square errors (RMS) and maximum value of position error. Figure 8 shows the time series of position errors in the east and north direction for schemes 1 and 2. Both sets of figures show that the proposed GPS/INS/odometer integrated system provides the better navigation results when a long GPS outage is encountered. The proposed scheme shows that with reliable training, it can decrease a 112 m error to 35 m in terms of 2-D position. Scheme 2 still provides accurate position information beyond a GPS signal absence of 10 minutes. Compared to scheme 1, the proposed GPS/INS/odometer scheme improves all the errors of position error in the north and east directions by 78% and 62% RMS, respectively.
Position error comparison: (left) position error in north; (right) position error in east.
Comparison of two schemes in terms of position error.
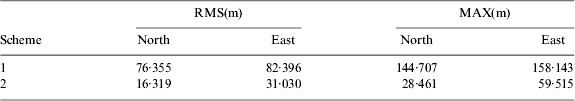
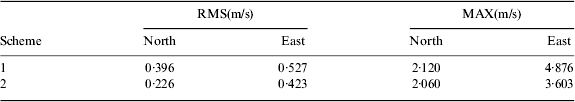
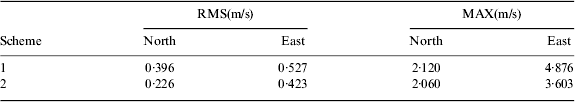
Table 4 shows the velocity improvement realized by the GPS/INS/odometer scheme proposed in the paper. Figure 9 plots the integrated system velocity errors in north and east directions respectively. The results show that the velocity of scheme 2 can achieve an accuracy of 0·226 m/s and 0·423 m/s in the north and east coordinate components, respectively. Compared to scheme 1, the proposed GPS/INS/odometer scheme improves all the errors of velocity error in the north and east direction by 43% and 20% RMS, respectively. The improvement of the velocity parameters is less than the position parameters.
Velocity error comparison: (left) velocity error in north; (right) velocity error in east.
Comparison of two schemes in terms of velocity error.
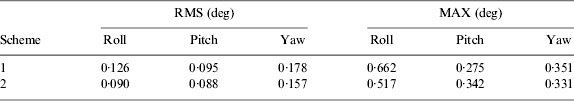
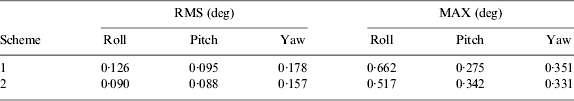
The roll, pitch and yaw errors of scheme 1 and scheme 2 are given in Table 5 and Figure 10. Compared to scheme 1, the proposed GPS/INS/odometer scheme improves all the errors of roll angles, pitch angles, and yaw angles by 29%, 7%, and 12% RMS, respectively. The improvement of the attitude parameters is the least in all parameters (position, velocity and attitude). The aiding of the FNN method barely improves the attitude solution. It is seen from the figures that integrated systems aided by FNN achieve the proposed suppression of the errors in conventional GPS/INS/odometer integrated navigation. The improvement of the velocity and attitude parameters is less than the position parameters. In order to obtain the high accuracy velocity observation from the odometer in the NED frame, the IMU sensor in INS/odometer has a high-precision gyroscope and accelerometer output, which is the most important influence to velocity and attitude precision. So the improvement of the velocity and attitude parameters is minimal in the proposed method.
The attitude error comparison: (a) attitude error in roll; (b) attitude error in pitch; (c) attitude error in yaw.
Comparison of two schemes in terms of attitude error.
6. CONCLUSIONS
This paper proposes a GPS/INS/odometer integrated system with a fuzzy neural network to improve the accuracy of position, velocity and attitude parameters during long GPS outages. In particular, a FNN system is designed to predict the correction of odometer measurement in the loss of GPS signals. Real measurements were used to demonstrate the performance of this approach.
The GPS and odometer system are able to sense the same observation. The relationship between the GPS and odometer observations is rather tight. Hence it is reliable to use the odometer to predict the velocity error during long GPS outages. The accuracy of velocity measurement by the odometer corrected by FNN is improved.
The results indicate that the proposed integrated system can provide benefits in the accuracy of the navigation solution, compared to a conventional GPS/INS/odometer integrated system. The position and velocity error has been reduced in the north and east directions respectively, and the attitude error has been reduced in terms of roll, pitch and yaw respectively. From the results, it is observed that the proposed method decreases the two dimensions position error to 35 m when a ten minute long GPS outage occurs. In order to guarantee the position accuracy in long GPS outages, high-precision INS is required. For future work, the potential of the FNN for low cost INS in GPS/INS/odometer tightly integrated navigation systems should be investigated.
FINANCIAL SUPPORT
The work is partially sponsored by the Fundamental Research Funds for the Central Universities (grant number: 2013RC16); partially sponsored by the Program for New Century Excellent Talents in University (grant number: NCET-13-1019) and partially sponsored by A Project Funded by the Priority Academic Program Development of Jiangsu Higher Education Institutions (grant number: SZBF2011-6-B35).