

1. Introduction
Mikhael Gromov [
Reference Gromov8
] demonstrated that the key asymptotic characteristics of the classical hyperbolic space
 $\mathbb{H}^{n}$
can be encapsulated in a simple inequality involving quadruples of points. This inequality was adequate to establish a theory of general hyperbolic spaces, known as Gromov hyperbolic spaces. These spaces capture many of the global features of classical hyperbolic space while providing much greater flexibility. Gromov hyperbolic spaces represent a significant and well-researched class of metric spaces (see [
Reference Bridson and Haefliger3, Reference Herron, Shanmugalingam and Xie11, Reference Lindquist and Shanmugalingam15
]), encompassing all complete, simply connected Riemannian manifolds with sectional curvature everywhere less than a negative constant.
Bonk, Heinonen and Koskela [ Reference Bonk, Heinonen and Koskela2 ] developed a uniformising procedure for Gromov hyperbolic, geodesic and proper metric spaces, and obtained the following result:
Theorem 1·1. The conformal deformations
 $X_\epsilon$
of a proper, geodesic
 $\delta-$
hyperbolic space X are bounded
 $A(\delta)-$
uniform spaces for
 $0\lt\epsilon\leq \epsilon_0$
.
A metric space is said to be uniform if any two points can be joined by a path which is neither too close to the boundary nor too crooked, see Definition 2·1 for a precise formulation. Uniform domains were introduced independently by Martio and Sarvas [ Reference Martio and Sarvas16 ] and John [ Reference John12 ], many domains such as unit ball or upper half-plane in Euclidean domains serves as the examples of uniform domains. This class of domains became the ‘nice domains’ in several contexts including quasiconformal theory.
Motivated by the work of Bonk et al. [
Reference Bonk, Heinonen and Koskela2
], Butler [
Reference Butler5
] and Zhou, Ponnusamy and Rasila [
Reference Zhou, Ponnusamy and Rasila21
] independently developed unbounded counterparts of Theorem 1·1 using a density that is exponential in a Busemann function. Busemann functions are known as the distance functions on a space from a point at infinity (see [
Reference buyalo and Schroeder6
]). Zhou et al. [
Reference Zhou, Ponnusamy and Rasila21
] considered proper geodesic
 $\delta$
-hyperbolic spaces having at least two points on the Gromov boundary whereas Butler [
Reference Butler5
] considered complete geodesic
 $\delta$
-hyperbolic spaces which are roughly starlike from a point in the Gromov boundary.
‘Free quasiworld’ introduced by Väisälä refers to the extensive study of quasiconformal theory in infinite-dimensional Banach spaces where many of the conveniences of Euclidean spaces are absent (see [ Reference Väisälä18 ]). For instance, in this setting the space is not locally compact and he has demonstrated that existence of geodesics is not guaranteed. He has also developed a foundational theory for more general hyperbolic spaces, which do not necessarily need to be geodesic or proper [ Reference Väisälä20 ], and thereby established the connections between hyperbolic and uniform domains in Banach spaces (see [ Reference Väisälä19 ]).
Before proceeding, we fix some necessary notation.
Notation 1·2. In this paper, X denotes a metric space and
 $|x-y|$
is the distance between points
 $x, y\in X$
. By a curve
 $\gamma$
in X, we mean a continuous function
 $\gamma\;:\;[a, b] \rightarrow X$
. An arc is a subset homeomorphic to a real closed interval. We adopt the convention of using
 $\gamma$
to denote the parametrisation of the curve as well as the image of the curve in X. To indicate that
 $\alpha$
is a curve or arc joining x and y, we write
 $\alpha \;:\;x\;{\curvearrowright}\; y$
. The length of a rectifiable curve
 $\gamma$
is denoted by
 $l(\gamma)$
.
Motivated by the works of Butler [ Reference Butler5 ] and Zhou et al. [ Reference Zhou, Ponnusamy and Rasila21 ], we investigate whether such a uniformisation procedure with Busemann functions exists for intrinsic spaces which need not be geodesic or proper.
Definition 1·3 (Intrinsic space). A metric space X is intrinsic if
 \[|x-y|= \inf \left\{ l(\gamma)| \gamma\;:\; x\;{\curvearrowright}\; y\right\},\]
for all
 $x, y\in X$
.
Following Väisälä [ Reference Väisälä20 ], we use the term ‘intrinsic’, although such spaces are often called length spaces or path-metric spaces in the literature. Notably, Butler explicitly raised the question of whether his results could be generalised to the setting of length spaces that are not necessarily geodesic (see [ Reference Butler5 , remark 1·8]).
The main ingredient in the proof of Theorem 1·1 was the Gehring–Hayman Theorem [
Reference Bonk, Heinonen and Koskela2
, theorem 5·1] for conformal deformations of hyperbolic spaces, which was also used by Butler [
Reference Butler5
] and Zhou et al. [
Reference Zhou, Ponnusamy and Rasila21
]. The name is inspired from the work of Gehring and Hayman [
Reference Gehring and Hayman7
], which established that the hyperbolic geodesic within a simply connected hyperbolic domain in the plane minimises the Euclidean length among all curves in the domain with same endpoints, up to a universal multiplicative constant. This theorem has been extended to quasihyperbolic geodesics in
 ${\mathbb{R}}^n$
that are quasiconformally equivalent to uniform domains (see [
Reference Heinonen and Näkki9
,
Reference Heinonen and Rohde10
]). In 2003, Balogh and Buckley [
Reference Balogh and Buckley1
] characterised Gromov hyperbolic domains in
 $\mathbb{R}^n$
using Gehring–Hayman property and ball separation condition. Recently, this topic has attracted substantial interest among researchers, see [
Reference Koskela and Lammi13, Reference Li, Pu and Wang14, Reference Rogovin, Shibahara and Zhou17
] and the references therein.
Because we are concerned with spaces that are not necessarily geodesic, the Gehring–Hayman theorem established in [ Reference Bonk, Heinonen and Koskela2 , theorem 5·1] does not apply. However, despite the absence of geodesics, we show that there exists a family of h-short arcs which serves as a substitute.
Definition 1·4. Let
 $h\geq 0$
. An arc
 $\alpha\;:\; x\;{\curvearrowright}\; y$
in a space X is h-short if
 $l(\alpha) \leq |x-y|+h.$
Using this family, we establish an analogue of the Gehring–Hayman theorem. We denote by
 $l_\rho(\gamma)$
the length of the curve
 $\gamma$
in the conformal deformation of a metric space X with the conformal factor
 $\rho$
. See Section 3 for details (see also [
Reference Bonk, Heinonen and Koskela2
, chapter 2]).
Theorem 1·5. Let X be an intrinsic
 $(\kappa, h)$
-Rips metric space (see Definition 2·7). Suppose
 $\rho\; :\;X{\rightarrow} (0, \infty)$
is a continuous function such that for some constants
 $\epsilon \gt 0$
and
 $\lambda \geq 1$
,
 \begin{equation} \frac{1}{\lambda}\exp\{-\epsilon|x-y|\} \leq \frac{\rho(x)}{\rho(y)} \leq \lambda \exp\{\epsilon|x-y|\}\end{equation}
holds for all
 $x,y \in X$
.
Let
 $h \lt 1/13$
, and let
 $\mathcal{A}$
be the family of all h-short arcs
 $\alpha\;:\;x\;{\curvearrowright}\; y$
in X satisfying the length constraint
 $l(\alpha) \leq 2|x-y|$
.
Then, there exist constants
 $\epsilon_0(\kappa, h)\gt 0$
and
 $K(\kappa, h)\gt 0$
such that for any
 $0 \lt \epsilon \leq \epsilon_0$
,
 \begin{equation}l_\rho(\alpha) \leq K l_\rho (\gamma)\end{equation}
holds for any curve
 $\gamma\;:\; x\;{\curvearrowright}\; y$
and any
 $\alpha \in \mathcal{A}$
connecting the same endpoints x and y.
We will apply Theorem 1·5 to prove that spaces obtained via conformal deformations with Busemann densities are uniform. Before stating this result, we introduce the specific construction of these deformations.
For the definition and further properties of the Busemann function see Subsection 2·2. We fix a point
 $\omega\in \partial_\infty X$
, the Gromov boundary of X (see (2·3) for the definition), and a Busemann function
 $b=b_{\omega, o}\in \mathcal{B}(\omega)$
with
 $o\in X$
. For
 $\epsilon \gt 0$
, define a family of maps
 $\rho_\epsilon \;:\;X \rightarrow (0, \infty)$
by
 \begin{equation}\rho_\epsilon (x) = e^{-\epsilon b(x)}.\end{equation}
Define a metric
 $d_\epsilon$
on X by
 \begin{equation}d_\epsilon(x, y) = \inf \int_\gamma \rho_\epsilon {\text{ ds}} ,\end{equation}
where the infimum is taken over all rectifiable curves
 $\gamma $
joining x and y. We denote the conformal deformation of X with conformal factor
 $\rho_\epsilon$
by
 $X_\epsilon = (X, d_\epsilon)$
. Note that, for any rectifiable curve
 $\gamma$
in X, the length of the curve
 $\gamma$
, denoted by
 $l_\epsilon\left(\gamma\right)$
, in the metric space
 $X_\epsilon$
is given by
 \begin{align*}l_\epsilon(\gamma)= \int_\gamma \rho_\epsilon {\text{ ds}},\end{align*}
provided the identity map
 $(X, |x-y|) \rightarrow (X, l)$
is a homeomorphism, where l is the intrinsic metric of X(see [
Reference Bonk, Heinonen and Koskela2
, lemma 2·6] and [
Reference Bonk, Heinonen and Koskela2
, appendix] for a detailed discussion).
Theorem 1·6. Let X be a complete intrinsic
 $\delta$
-hyperbolic space and suppose there are at least two points in the Gromov boundary of X. Then the conformal deformations
 $X_\epsilon = (X, d_\epsilon)$
are unbounded uniform spaces for
 $0\leq\epsilon\leq\epsilon_0(\delta)$
.
We also prove that there exists a natural identification of Gromov boundary of X with the boundary of the deformed space
 $X_\epsilon$
.
Theorem 1·7. Let X be a complete intrinsic
 $\delta$
-hyperbolic space and
 $b_{\omega, o} \in \mathcal{B}(\omega)$
be a Busemann function. Suppose there exists at least two points in the Gromov boundary of X. Then there exists a natural identification between
 $ \partial_\infty X\setminus \{\omega\} $
and the boundary of the deformed space
 $X_\epsilon$
for
 $0\leq \epsilon\leq \epsilon_0(\delta)$
.
Remark 1·8. The motivation for Väisälä to construct a theory of general Gromov hyperbolic spaces was the fact that the domains in Banach spaces when equipped with quasihyperbolic metric were intrinsic but not geodesic. Hence, domains of these kind does not come under the works of Zhou et al. [ Reference Zhou, Ponnusamy and Rasila21 ] or Butler [ Reference Butler5 ]. Note that, while Butler’s work did not employ properness arguments, it focused on geodesic metric spaces, whereas our study considers spaces that are neither proper nor geodesic. Furthermore, his results rely heavily on tripod maps, which are unavailable in non-geodesic metric spaces. Also, we do not require our spaces to be roughly starlike. Hence, Theorem 1·6 and Theorem 1·7 are improvements of [ Reference Butler5 , theorem 1·4, theorem 1·6].
We realise in the study of non-proper Gromov hyperbolic spaces which are not necessarily geodesic some concepts are more complicated than in the classical case, such as the center of an h-short triangle consists of three arcs instead of three points as in the classical case. Also, since there are no geodesic rays and geodesic lines, Väisälä constructed the concepts of roads and bi-roads which are more clumsier. But, as bounded distortions do not affect the structure of the space in large scale, we emphasise that the study of more general metric spaces is more suited to the philosophy of Gromov hyperbolic spaces. Also, we point out that the study of Gromov hyperbolic domains which are not geodesic is not new. In 2000, Bonk and Schramm [ Reference Bonk and Schramm4 ] introduced the concepts of almost geodesic and roughly geodesic hyperbolic spaces. Also, note that the example of Con(Z) constructed by them was not geodesic but roughly geodesic.
The organisation of the paper is as follows. In Section 2, we give some basic definitions and preliminary results. Section 3 is dedicated to the proof of Theorem 1·5. In Section 4, we provide the proofs of Theorem 1·6 and Theorem 1·7.
2. Preliminaries
Geodesics in a space are the isometric image of an interval in
 $\mathbb{R}$
. We observe that
 $\alpha $
is a geodesic if and only if it is 0-short and a space X is intrinsic if and only if for each pair
 $x, y\in X$
and for every
 $h\gt 0$
there is an h-short arc connecting them. It is easy to see that every subarc of an h-short arc is h-short. For any curve
 $\gamma$
, and for
 $u, v\in \gamma$
, we use
 $\gamma[u,v]$
to denote the subcurve of
 $\gamma$
joining u and v. For any rectifiable curve
 $\gamma\;:\;[a, b] \rightarrow X$
, there is an arclength parametrisation
 $\psi\;:\;[0, l(\gamma)] \rightarrow \gamma$
such that
 $l\left(\gamma(s, t)\right) = |s-t|$
for every
 $s, t\in [0, l(\gamma)]$
. We frequently use this fact in our proofs.
Definition 2·1. Let X be an rectifiably connected, incomplete metric space. It is called
 $A-$
uniform if every pair of points
 $x, y\in X$
can be joined by a curve
 $\gamma$
in X satisfying
 \begin{equation} l(\gamma) \leq A |x-y|\end{equation}
and
 \begin{equation} \min\left\{l\left(\gamma[x, z]\right), l\left(\gamma[z, y]\right)\right\}\leq A d(z),\end{equation}
where d(z) is the distance of z to the boundary
 $\partial X = \overline{X}\setminus X$
of X. Here
 $\overline{X}$
denotes the metric completion of the space X.
The condition (2·1) is known as quasiconvexity of the curve and (2·2) is known as the double cone arc condition. We employ the standard notations of representing balls in X as
 \begin{align*}B(a, r) = \{x\in X\;:\; |x-a|\lt r\} \text{ and } \bar{B}(a, r)= \{x\in X\;:\; |x-a|\leq r\}.\end{align*}
For a non empty set
 $A\subset X$
,
 $N_r(A)$
be the r-neighbourhood of A defined as
 \begin{align*}N_r(A) = \{x\in X \;:\; d(x, A) \lt r\}.\end{align*}
2·1. Gromov hyperbolic spaces
Definition 2·2. For
 $x, y, p\in X$
we define the Gromov product
 $(x|y)_p$
by
 \begin{align*}2(x|y)_p = |x-p|+|y-p|-|x-y|.\end{align*}
Let
 $\delta \geq 0$
. A space is Gromov
 $\delta$
-hyperbolic if
 \begin{align*}(x|z)_p \geq \min\left\{(x|y)_p , (y|z)_p\right\} -\delta\end{align*}
for all
 $x, y, z, p\in X$
. A space is hyperbolic if it is Gromov
 $\delta$
-hyperbolic for some
 $\delta\geq 0$
.
A classical example of a hyperbolic space is the Poincaré half space in
 ${\mathbb{R}}^n$
with the hyperbolic metric. In general, Väisälä [
Reference Väisälä20
] has shown that uniform domains equipped with the quasihyperbolic metric in arbitrary Banach spaces are hyperbolic. Bounded spaces are trivially hyperbolic, hence we make the assumption that every Gromov hyperbolic space we consider in this paper is unbounded.
Definition 2·3. Let X be a metric space and let
 $o\in X$
be fixed. We say that a sequence
 $\{x_n\} $
in X is a Gromov sequence if
 $(x_i|x_j)_o \rightarrow \infty$
as
 $i\rightarrow \infty$
and
 $j\rightarrow \infty$
.
We say that two Gromov sequences
 $\{x_n\}$
and
 $\{y_n\}$
are equivalent if
 $(x_i|y_i)_o \rightarrow \infty $
as
 $i\rightarrow \infty$
. In a hyperbolic space this is indeed an equivalence relation. Let
 $\hat{x} $
be the equivalence class containing the Gromov sequence
 $\{x_n\} $
. The Gromov boundary
 $\partial_\infty X $
is defined as
 \begin{equation} \partial_\infty X = \left\{ \hat{x}\;:\; \{x_n\} \text{ is a Gromov sequence in } X\right\}.\end{equation}
For
 $\zeta, \eta \in \partial_\infty X$
we define
 \begin{align*}(\zeta |\eta)_o = \inf \{\liminf_{i,j\rightarrow \infty} (x_i|y_j)_o\;:\; \{x_i\}\in \zeta, \{y_i\}\in \eta \}.\end{align*}
Lemma 2·4. Let X be a
 $\delta$
-hyperbolic space with
 $z, o\in X$
and
 $\zeta, \eta \in \partial_\infty X$
. Then for
 $\{x_i\}\in \zeta$
and
 $\{y_i\}\in \eta$
, we have
 \begin{align*}(\zeta | \eta)_o \leq \liminf(x_i|y_i)_o \leq \limsup (x_i|y_i)_o \leq (\zeta | \eta)_o+2\delta ,\\(\zeta | z)_o \leq \liminf(x_i|z)_o \leq \limsup (x_i|z)_o \leq (\zeta | z)_o+\delta .\end{align*}
We need the following result by Väisälä [ Reference Väisälä20 , tripod lemma 2·15].
Lemma 2·5. Suppose that
 $\alpha_i \;:\;a\;{\curvearrowright}\; b_i, i=1,2,$
are h-short arcs in a
 $\delta$
-hyperbolic space. Let
 $x_1\in \alpha_1$
be a point with
 $|x_1 -a| \leq (b_1|b_2)_a$
, and let
 $x_2, x_2' \in \alpha_2$
be points with
 $|x_2-a|=|x_1-a|$
and
 $l\left(\alpha_2[a, x_2']\right) = l\left(\alpha_1[a, x_1]\right)$
. Then
 \begin{align*}|x_1-x_2| \leq 4\delta +h, |x_1-x_2'| \leq 4\delta+2h.\end{align*}
Definition 2·6 (Triangles). By an h-short triangle we mean a triple of h-short arc
 $\alpha \;:\; y\;{\curvearrowright}\; z$
,
 $\beta \;:\; x\;{\curvearrowright}\; z$
,
 $\gamma\;:\; x\;{\curvearrowright}\; y$
. The points x, y, z are the vertices and the arcs
 $\alpha, \beta, \gamma$
are the sides of the triangle
 $\Delta=\left(\alpha, \beta, \gamma\right)$
.
Following the notations used by Väisälä [
Reference Väisälä20
], we let
 $x_\gamma, y_\gamma$
be the points in
 $\gamma $
such that
 $l(\gamma_x)= (y|z)_x$
and
 $l(\gamma_y)= (x|z)_y$
, where
 $\gamma_x = \gamma[x, x_\gamma]$
and
 $\gamma_y = \gamma[y_\gamma, y]$
. If we set
 $\gamma^*= \gamma[x_\gamma, y_\gamma]$
which is called the center of the side
 $\gamma$
in the triangle
 $\Delta$
, then
 $\gamma$
is the union of three subarcs
 $\gamma_x, \gamma^*, \gamma_y$
.
The following condition is an equivalent definition for Gromov hyperbolic spaces in terms of slim triangles. See Section 3 for a further discussion.
Definition 2·7 (Rips condition). Let
 $\delta \geq 0$
. A triangle
 $\Delta$
in a space X is
 $\delta$
-slim if each side
 $\tau$
of
 $\Delta$
is contained in
 $\bar{B}\left(|\Delta|\setminus \tau, \delta\right)$
, where
 $|\Delta|= \alpha \cup \beta\cup \gamma$
. We say that an intrinsic space X is
 $(\delta, h)$
-Rips, if every h-short triangle in X is
 $\delta$
-slim.
We also need the following lemma in establishing the Gehring–Hayman theorem.
Lemma 2·8 (Projection lemma). [
Reference Väisälä20
, lemma 3·6] Suppose X is an intrinsic
 $(\kappa, h)$
-Rips space. Let
 $\gamma\subset X$
be an h-short arc and let
 $x_1, x_2\in X$
and
 $y_1, y_2\in \gamma$
be points such that:
-
(i)
 $|x_i-y_i| = d\left(x_i, \gamma\right)\geq R \gt 0$
for
$i=1, 2;$
-
(ii)
$|x_1-x_2| \lt 2R-4\kappa -h$
.


Then
 $|y_1-y_2| \leq 8\kappa +2h$
.
In a proper, geodesic, hyperbolic space any point in the Gromov boundary and any point in X can be joined by a geodesic ray. But in the case of general intrinsic hyperbolic spaces we do not have that luxury. Väisälä [ Reference Väisälä20 ] introduced the concept of ‘roads’ to overcome this difficulty.
Definition 2·9. Let X be a metric space and let
 $\mu \geq 0$
,
 $h\geq 0$
. A
 $(\mu, h)$
-road in X is a sequence
 $\bar{\alpha}$
of arcs
 $\alpha_i\;:\;y\;{\curvearrowright}\; u_i$
with the following properties:
-
(1) each
$\alpha_i$
is h-short; -
(2) the sequence of lengths
$l(\alpha_i)$
is increasing and tends to
$\infty$
; -
(3) for
$i\leq j$
, the length map
$g_{ij}\;:\;\alpha_i \rightarrow \alpha_j$
with
$g_{ij}y=y$
satisfies
$|g_{ij}x-x|\leq \mu $
for all
$x\in \alpha_i$
.


It is possible to join any point in X to any point in the boundary
 $\partial_\infty X$
by
 $(4\delta+2h, h)$
-road.
2·2. Busemann functions
We refer the reader to [ Reference buyalo and Schroeder6 , chapter 3] for a detailed discussion on the topic (see also [ Reference Bridson and Haefliger3 ]).
Notation 2·10. Let a, b, C be constants, following the notations in [
Reference buyalo and Schroeder6
], we write
 $a\dot{=}_C b$
if
 $|a-b|\leq C$
. If
 $a, b\gt 0$
and
 $C\geq 1$
then we write
 $a\asymp_C b $
instead of
 $1/C b \leq a \leq C b$
. Also, we sometimes avoid mentioning the constant C if it is not important, and just write
 $\dot{=}, \asymp$
instead of
 $\dot{=}_C, \asymp_C$
, respectively.
We recall the definition of the Busemann function. While it is possible to define it using geodesic rays (see [ Reference Bridson and Haefliger3, Reference Butler5 ]) provided the space admits them, we present the definition based on the Gromov product.
Definition 2·11. Let X be a
 $\delta$
-hyperbolic space. For any
 $\omega \in \partial_\infty X$
, the Gromov boundary of X, the function
 \begin{equation} b_\omega\;:\; X\times X \rightarrow {\mathbb{R}},\,\,\, b_\omega(x, y) = (\omega | y)_x -(\omega |x )_y\end{equation}
is well defined. We let
 $\mathcal{B}(\omega) \subset {\mathbb{R}}^X $
be the set which consists of all functions
 $b\;:\; X{\rightarrow} {\mathbb{R}}$
for each of which there are
 $o\in X$
and constant
 $c\in {\mathbb{R}}$
with
 $b(x) = b_{\omega, o}(x)+c $
, where
 $b_{\omega, o}(x) = b_\omega(x, o)$
. Any function from
 $\mathcal{B}(\omega)$
is called a Busemann function based at
 $\omega \in\partial_\infty X$
.
We will primarily focus on the canonical functions
 $b_{\omega, o}$
, where
 $o\in X$
and
 $\omega \in \partial_\infty X$
. Every Busemann function
 $b \in \mathcal{B}(\omega)$
is roughly 1-Lipschitz, that is
 \begin{equation} |b(x) - b(x')| \leq |x-x'|+ 10 \delta\end{equation}
for every
 $x, x'\in X$
. Also, for every
 $\omega \in\partial_\infty X$
, every sequence
 $\{u_n\}\in \omega$
and every
 $o, x \in X$
it is known that (see [
Reference buyalo and Schroeder6
, lemma 3·1·1])
 \begin{equation} b_\omega(x, o) \dot{=}_{2\delta} (u_n|o)_x - (u_n|x)_o = |u_n-x|-|u_n-o|.\end{equation}
We provide a few examples of Busemann functions below.
Example 2·12.
-
(1) Let X be a
$\delta$
-hyperbolic space. For every
$o\in X$
, the function
$\beta_{\omega, o}(x) = |o-x| - 2(\omega|x)_o$
is a Busemann function based at
$\omega \in \partial_\infty X$
. Furthermore, we have:
\[b_{\omega, o}(x) \leq \beta_{\omega, o}(x) \leq b_{\omega, o}(x)+2\delta.\]
-
(2) Let
$\mathbb{H}^2$
be the upper-half plane equipped with the hyperbolic metric. Then for
$z=x+i y$
, the function
$b(z)= - \ln (y)$
is a Busemann function based at the Gromov boundary point
$\infty$
. -
(3) Consider the Poincaré disc model for the hyperbolic space
$\mathbb{H}^n$
. Then for
$|z|\lt 1 $
and
$|\xi|=1$
, the Busemann function is given bywhere
\[b_{\xi}(z) = -\ln \left(\frac{1-|z|^2}{|\xi - z|^2}\right),\]
$|\cdot|$
denotes the Euclidean norm and the term inside the logarithm is the Poisson kernel.


Recalling the definition of
 $\rho_\epsilon(x)$
from (1·3) and applying (2·5), we derive the following Harnack-type inequality:
 \begin{equation}e^{-10\epsilon \delta}\exp\{-\epsilon|x-y|\} \leq \frac{\rho_\epsilon(x)}{\rho_\epsilon(y)}\leq e^{10\epsilon \delta}\exp\{\epsilon|x-y|\}.\end{equation}
This shows that the densities satisfy (1·1).
Busemann functions can be used to define a Gromov product based at
 $\omega \in \partial_\infty X$
. For a fixed Busemann function
 $b\in \mathcal{B}(\omega)$
and
 $x, y\in X$
the product is defined as
 \begin{equation*}2(x|y)_b= b(x)+b(y)-|x-y|.\end{equation*}
Note that here
 $(x|y)_b$
can be negative, contrary to the standard case. Also, from the discussion in [
Reference buyalo and Schroeder6
, section 3·2] we obtain that
 \begin{equation} (x|y)_b \dot{=}_{10\delta} (x|y)_o - (x|\omega)_o - (w|y)_o\end{equation}
for
 $b\in \mathcal{B}(\omega)$
.
3. Gehring–Hayman Theorem
Let X be an intrinsic,
 $(\kappa, h)$
-Rips space, and let
 $\rho \;:\;X{\rightarrow} (0, \infty)$
be a continuous function that satisfies (1·1) for all
 $x,y \in X$
and
 $\epsilon \gt 0$
. It is easy to verify that such a continuous function
 $\rho$
determines a metric space
 $(X, d_\rho),$
where the new metric is given by
 \begin{align*}d_\rho(x, y) = \inf \int_\gamma \rho {\text{ ds}};\end{align*}
and the infimum is taken over all rectifiable curves
 $\gamma$
joining x and y. Also, if the identity map
 $\left(X, |\cdot|\right) {\rightarrow} \left(X, l\right)$
, where
 $l(x, y)= \inf_\gamma l(\gamma)$
, is a homeomorphism, then for each rectifiable curve
 $\gamma$
then length of
 $\gamma$
in the metric space
 $(X, d_\rho)$
denoted by
 $l_\rho$
is given by
 \begin{align*}l_\rho(\gamma)=\int_\gamma \rho {\text{ ds}}.\end{align*}
Note that, the
 $(\delta, h)$
-Rips condition is quantitatively equivalent to
 $\delta$
-hyperbolicity. Precisely, a
 $\delta$
-hyperbolic space is
 $(\kappa, h)$
-Rips with
 $\kappa= 3\delta+3h/2$
(see [
Reference Väisälä20
, theorem 2·34, theorem 2·35]. Hence, in this section we suppose that X is
 $(\kappa, h)$
-Rips and obtain the constants depending on
 $\kappa$
and h. For a
 $\delta$
-hyperbolic space one can always obtain the constants in terms of
 $\delta$
by simply substituting
 $\kappa=3\delta+3h/2$
.
The proof of Theorem 1·5 is accomplished through a series of lemmas. We employ techniques similar to those used by Bonk et al. [
Reference Bonk, Heinonen and Koskela2
, chapter 5]. However, the lack of geodesics complicates the proofs significantly. We note that in the absence of geodesics, h-short arcs exhibit properties akin to geodesics if we select a sufficiently small
 $h\gt 0$
.
Lemma 3·1. Let
 $\gamma \;:\;x\;{\curvearrowright}\; y $
be a curve in X satisfying
 \begin{equation} |x-y| \leq L=\frac{1}{24\lambda^2 \epsilon}\end{equation}
and
 \begin{equation} l(\gamma) \geq 6\lambda^2 |x-y|.\end{equation}
Then
 $l_\rho(\alpha) \leq l_\rho(\gamma)$
where
 $\alpha\;:\;x\;{\curvearrowright}\; y $
is such that
 $l(\alpha)\leq 2|x-y|$
.
Proof. To estimate the length
 $l_\rho(\alpha)$
, we rely on the Harnack-type inequality of
 $\rho$
given in (1·1), combined with the bound
 $|x-y|\leq l(\alpha) \leq 2|x-y|$
. Using (1·1) to bound the density
 $\rho$
and applying the length bound to the domain of integration, we compute
 \begin{align*}l_\rho(\alpha) &=\int_\alpha \rho {\text{ ds}}\\&\leq \lambda \rho(x)\int_0^{2|x-y|}e^{\epsilon t} {\text{ dt}}\\& \leq \lambda \rho(x) \frac{1}{\epsilon} (e^{2\epsilon|x-y|}-1.)\end{align*}
Since,
 $e^\tau-1\leq {3}/{2}\tau $
whenever
 $0\leq \tau \leq {1}/{4}$
and from (3·1) we obtain
 \begin{align*}l_\rho(\alpha) \leq 3\lambda \rho(x)|x-y|.\end{align*}
Meanwhile, using (3·2) we calculate
 \begin{align*}l_\rho(\gamma) &\geq \frac{\rho(x)}{\lambda}\int_0^{6\lambda^2|x-y|}e^{-\epsilon t}{\text{ dt}}\\&=\frac{\rho(x)}{\lambda}\frac{1}{\epsilon} (1- e^{-\epsilon 6\lambda^2|x-y|})\\&\geq 4\lambda\rho(x)|x-y|.\end{align*}
The last step follows from (3·1) and the fact that
 $1-e^{-\tau} \geq {2}/{3}\tau $
whenever
 $0\leq \tau\leq {1}/{4}$
. Hence the proof of Lemma 3·1 is complete.
Lemma 3·2. Let
 $\bar{\gamma} \;:\;x\;{\curvearrowright}\; y $
be any rectifiable curve in X then there is a curve
 $\gamma\;:\;x\;{\curvearrowright}\; y$
with
 $l_\rho(\gamma) \leq l_\rho(\bar{\gamma)}$
such that
 \begin{equation} l\left(\gamma[u, v]\right) \leq 6\lambda^2 |u-v|+1\end{equation}
whenever
 $|u-v|\leq {1}/{24\lambda^2 \epsilon}$
.
Proof. Let
 $\Gamma$
be the family of all curves in X joining x and y such that
 $l_\rho(\gamma)\leq l_\rho(\bar{\gamma})$
for any
 $\gamma \in \Gamma$
.
Clearly
 $\bar{\gamma} \in \Gamma$
and hence
 \begin{align*}S=\inf_{\gamma \in\Gamma} l(\gamma) \lt \infty.\end{align*}
Choose a curve
 $\gamma\in \Gamma$
such that
 $l(\gamma)\leq S+{1}/{2}$
. We claim that
 $\gamma$
is the required curve. If not, then there exists
 $u,v\in \gamma$
such that
 \begin{align*}|u-v| \lt \frac{1}{24\lambda^2 \epsilon}\end{align*}
but
 \begin{align*}l(\gamma[u, v]) \gt 6\lambda^2|u-v|+1.\end{align*}
Then by Lemma 3·1,
 $l_\rho (\alpha) \leq l_\rho (\gamma[u,v]),$
for a curve
 $\alpha\;:\;u\;{\curvearrowright}\; v$
such that
 $l(\alpha)\leq 2|u-v|$
.
Construct a new curve
 $\gamma' = \gamma[x,u] \cup \alpha \cup \gamma[v,y].$
It is easy to verify that
 $\gamma'\in \Gamma$
and hence we obtain
 \begin{align*}S\leq l(\gamma') &= l(\gamma[x,u])+l(\alpha)+l(\gamma[v,y])\\&=l(\gamma)-l(\gamma[u,v])+l(\alpha)\\&\leq S+\frac{1}{2}-(6\lambda^2|u-v|+1)+2|u-v|\\&\leq S-\frac{1}{2}\end{align*}
which is the desired contradiction and the proof is complete.
Lemma 3·3. Let M,C,L be positive numbers and let
 $\gamma \;:\;x\;{\curvearrowright}\; y$
be a rectifiable curve satisfying
 \begin{equation} l\left(\gamma[u,v]\right)\leq M|u-v|+C\end{equation}
whenever
 $|u-v|\leq L$
. Let
 $0\lt h\lt\min \left\{1, {1}/({1+2M})\right\}$
and if for some h-short arc
 $\beta$
it holds that
 \begin{equation} {\text{ dist}}\left(\gamma, \beta\right)={\text{ dist}}\left(x, \beta\right) ={\text{ dist}}\left(y, \beta\right) \geq R,\end{equation}
where
 $R=1+4\kappa+4\kappa M+2h$
, then either
 \begin{equation} |x-y|\gt L\end{equation}
or
 \begin{equation} |x-y| \leq A(\kappa, h, M, C).\end{equation}
Proof. Let
 $x_0, y_0 \in \beta$
be points such that
 \begin{align*}|x-x_0|=|y-y_0|= {\text{ dist}}(\gamma, \beta).\end{align*}
Further, let
 $\beta_1\;:\;x\;{\curvearrowright}\; x_0$
and
 $\beta_2\;:\;y\;{\curvearrowright}\; y_0$
be h-short arcs. By assumption (3·5) we can choose points
 $x_1\in \beta_1$
and
 $y_1\in \beta_2$
such that
 \begin{align*}|x-x_1|=R=|y-y_1|.\end{align*}
Again, let
 $\beta_3\;:\;x_1 \;{\curvearrowright}\; y_1$
be an h-short arc.
We claim that
 \begin{equation} {\text{ dist}}(\gamma, \beta_3) \geq r\;:\!=\;R-2\kappa-2h = 1+2\kappa+4\kappa M.\end{equation}
If otherwise, there will exist points
 $z\in \gamma$
and
 $z_1\in \beta_3$
such that
 $|z-z_1|\lt r$
. On one hand, by applying
 $(\kappa, h)$
-Rips condition to the h-short rectangle
 $\beta_1[x_1,x_0]\cup\beta_2[y_1, y_0]\cup\beta_3\cup \beta[x_0, y_0]$
, we obtain a point
 $z_0 \in \beta_1[x_1,x_0]\cup\beta_2[y_1, y_0]\cup \beta[x_0, y_0]$
such that
 $|z_1-z_0|\leq 2\kappa.$
On the other hand, we will show that such a point cannot belong to any of these curves and thereby reach at a contradiction.
If
 $z_0 \in \beta[x_0, y_0]$
, then
 \begin{align*}R\leq |z_0-z| \leq |z_0-z_1| + |z_1-z| \lt r+2\kappa \lt R,\end{align*}
a contradiction.
If
 $z_0\in \beta_1[x_1, x_0]$
, we then compute
 \begin{align*}|x-x_0| &= {\text{ dist}}(\gamma, \beta) \leq {\text{ dist}}(z, \beta)\\&\leq |z-z_1|+|z_1-z_0|+|z_0-x_o|\\&\lt r+2\kappa + |x_1-x_0|+h\\&=R-h + |x_1-x_0|\\&=|x-x_1|+|x_1-x_0|-h\\&\leq l\left(\beta_1\right)-h\\&\leq |x-x_0|,\end{align*}
again a contradiction and hence
 $z_0\notin \beta_1[x_1, x_0]$
. Similarly, one can show that
 $z_0\notin \beta_2[y_1, y_0]$
. Thus the inequality (3·8) follows.
Now, we find points
 $x=u_0, u_1,...,u_{n-1}, u_n=y$
in
 $\gamma$
, where
 $n\geq 1$
, such that
 \begin{align*}l\left(\gamma[u_k, u_{k+1}]\right) &= 1+8\kappa M-h, \text{ for } 0\leq k \leq n-2, \\l\left(\gamma[u_{n-1}, u_n]\right) &\leq 1+8\kappa M-h .\end{align*}
Clearly,
 \begin{equation} |u_k-u_{k+1}| \leq 1+8\kappa M \lt 2r-4\kappa -h\end{equation}
since
 $h\lt 1$
.
Next, choose
 $v_k\in \beta_3 $
such that
 \begin{equation} |u_k-v_k|={\text{ dist}} (u_k,\beta_3).\end{equation}
Now, (3·8), (3·9) and (3·10) together with the projection lemma (Lemma 2·8) yield us
 \begin{align*}|v_k-v_{k+1}| \leq 8\kappa+2h\end{align*}
for
 $0\leq k\leq n-1$
. Observe that
 \begin{align*}|u_0-v_0| = {\text{ dist}} (x, \beta_3)\leq |x-x_1| =R\end{align*}
and a similar argument gives that
 $|u_n-v_n|\leq R$
.
We are now ready to prove the lemma. Assume that
 $|x-y|\leq L$
, then by (3·4) we have
 \begin{align*}l(\gamma)\leq M|x-y|+C.\end{align*}
Thus,
 \begin{align*}n\leq \frac{l(\gamma)}{1+8\kappa M-h}+1 \leq \frac{ M|x-y|+C}{1+8\kappa M-h}+1 .\end{align*}
Hence,
 \begin{align*}|x-y|&=|u_0-u_n| \\&\leq |u_0-v_0| +\sum_{k=0}^{n-1} |v_k-v_{k+1}| + |u_n-v_n|\\&\leq 2R + n (8\kappa +2h)\\&\leq 2R+(8\kappa +2h)\frac{ M|x-y|+C}{1+8\kappa M-h}+ 8\kappa +2h.\end{align*}
An elementary computation gives us
 \begin{align*}|x-y| \leq \frac{1}{1-h-2hM}\left(2R+8\kappa +2h\right)(1+8\kappa M-h) +\frac{(8\kappa+2h)C}{1-h-2hM},\end{align*}
we let
 \begin{equation}A\;:\!=\; \frac{1}{1-h-2hM}\left(2R+8\kappa +2h\right)(2+8\kappa M-h) +\frac{(8\kappa+2h)C}{1-h-2hM}\end{equation}
then it follows that
 $|x-y|\leq A$
, which is the desired result and the proof is complete.
Lemma 3·4. Let
 $\gamma\;:\;x\;{\curvearrowright}\; y $
be a rectifiable curve satisfying
 \begin{equation} l(\gamma[u, v]) \leq M|u-v|+C\end{equation}
whenever
 $|u-v|\leq L\;:\!=\;2M( A +1)+1$
, where A is the constant as in (3·11). Then,
 $\gamma \subset B\left(\alpha, L\right)$
for every h-short arc
 $\alpha\;:\; x \;{\curvearrowright}\; y$
, provided
 $h\lt \min\left\{1, {1}/({1+2M})\right\}$
.
Proof. We first assume that the curve
 $\gamma$
is parametrised by the arclength. That is,
 ${\gamma\;:\;}[0, l(\gamma)] \rightarrow X$
is such that
 $l\left(\gamma(s, t)\right) = |s-t|$
for every
 $0\leq s\leq t\leq l(\gamma)$
. Let
 $\alpha$
be an h-short arc with endpoints x and y. We define
 $f\;:\;[0, l(\gamma)]\rightarrow [0, \infty)$
such that
 $f(t) ={\text{ dist}} \left(\gamma(t), \alpha\right).$
We claim that f satisfies all the conditions of [
Reference Bonk, Heinonen and Koskela2
, lemma 5·15].
Since, both
 $\gamma$
and
 $\alpha$
have the same endpoints, it is evident that
 $f(0)=f(l(\gamma))=0$
. Also for
 $s,t\in [0, l(\gamma)]$
, we have
 \begin{align*}|f(s)-f(t)|=|{\text{ dist}}\left(\gamma(s), \alpha\right) - {\text{ dist}}\left(\gamma(t), \alpha\right)|\leq |\gamma(s)-\gamma(t)| \leq l\left(\gamma(s, t)\right) =|s-t|.\end{align*}
We claim that f satisfies the third condition with the constant
 $c= {L}/{2}$
. Let
 $(s, t)\in M_c$
, then for each
 $r\in[s, t]$
 \begin{align*}{\text{ dist}} \left(\gamma(r), \alpha\right) \geq {\text{ dist}} \left(\gamma(s), \alpha\right)={\text{ dist}} \left(\gamma(t), \alpha\right)\geq \frac{L}{2} \geq R,\end{align*}
where
 $R= 1+4\kappa+4\kappa M+2h$
.
Hence, by Lemma 3·3, either
 $|u-v|\gt L$
or
 $|u-v|\leq A$
, where
 $u=\gamma(s)$
and
 $v=\gamma(t)$
.
If
 $|u-v|\gt L$
, then
 \begin{align*}2c=L \lt|\gamma(s)-\gamma(t)|\leq l\left(\gamma(s, t)\right)=t-s.\end{align*}
If
 $|u-v|\leq A$
, then
 \begin{align*}|\gamma(s)-\gamma(t)| \leq A \leq L.\end{align*}
Together with (3·12), this yields
 \begin{align*}t-s=l\left(\gamma(s, t)\right) &\leq M.A+C \\&=\frac{1}{2}(L-1) \lt \frac{L}{2}=c.\end{align*}
Thus all the assumptions of [ Reference Bonk, Heinonen and Koskela2 , lemma 5·15] are satisfied, and it implies that
 \begin{align*}\max_{x\in [0, l(\gamma)]} f(x) \lt\frac{3}{2}c = \frac{3}{4}L \lt L\end{align*}
which completes the proof of the lemma.
Now, we are prepared to proceed with the proof of the theorem.
Proof of Theorem
1·5. Choose
 $M=6\lambda^2, C=1$
in Lemma 3·4 and let L be the constant given in Lemma 3·4. Choose,
 \begin{equation}\epsilon_0= \frac{1}{25\lambda^2 L}.\end{equation}
Let
 $\alpha \;:\; x\;{\curvearrowright}\; y $
be an h-short arc for
 $h \lt {1}/{13}$
satisfying
 $l(\alpha)\leq 2|x-y|$
and
 $\gamma \;:\;x\;{\curvearrowright}\; y$
be any other curve. Note that, for each
 $h\gt 0$
we can always select such a curve by choosing a curve
 $\alpha\;:\;x\;{\curvearrowright}\; y$
such that
 $l(\alpha) \leq c |x-y|$
, for
 $c= \min \left\{2, 1+h/|x-y|\right\}$
. According to Lemma 3·2, we can assume that
 $\gamma$
satisfies
 \begin{equation}l\left(\gamma[u, v]\right) \leq 6\lambda^2|u-v|+1\end{equation}
whenever
 $|u-v|\leq {1}/{24\lambda^2\epsilon}$
. Given the choice of
 $\epsilon_0$
, this implies that
 \begin{align*}|u-v| \leq \frac{25L}{24}.\end{align*}
Therefore,
 $\gamma $
satisfies the conditions of Lemma 3·4 with
 $M=6\lambda^2, C=1$
and thus
 $\gamma $
belongs to the L-neighbourhood of
 $\alpha$
. Furthermore, by [
Reference Väisälä20
, lemma 3·5],
 $\alpha$
belongs to
 $2L+h$
-neighbourhood of
 $\gamma$
, but clearly
 $2L+h \leq 3L$
and hence,
 \begin{equation}\alpha\subset B\left(\gamma, 3L\right)\end{equation}
We first consider the case when
 $|x-y| \leq 9L$
.
On one hand we have,
 \begin{align*}l_\rho(\alpha) &= \int_\alpha \rho {\text{ ds}} \leq \int_\alpha \lambda\rho(x) e^{\epsilon_0 |x-\alpha(t)|} {\text{ dt}}\\&\leq \int_\alpha \lambda\rho(x) e^{\epsilon_0 l\left(\alpha[x, \alpha(t)]\right)} {\text{ dt}}\\&\leq \int_\alpha \lambda\rho(x) e^{\epsilon_0 18L}{\text{ dt}}\\&\leq \lambda \rho(x) e^{\epsilon_0 18L} l(\alpha)\\&\leq 2\lambda \rho(x) e^{\epsilon_0 18L} |x-y|.\end{align*}
On the other hand, there exists a subcurve
 $\gamma'$
of the curve
 $\gamma\;:\; x\;{\curvearrowright}\; y$
emanating from x such that
 $l(\gamma')=|x-y|$
. Therefore, we compute
 \begin{align*}l_\rho(\gamma)\geq l_\rho(\gamma') &= \int_{\gamma'} \rho {\text{ ds}} \geq \int_{\gamma'} \frac{1}{\lambda}\rho(x) e^{-\epsilon_0|x-\gamma(t)|}{\text{ dt}}\\&\geq \int_{\gamma'} \frac{1}{\lambda} \rho(x) e^{-\epsilon_0|x-\gamma'(t)|}{\text{ dt}}\\&\geq \int_{\gamma'} \frac{1}{\lambda} \rho(x) e^{-\epsilon_0 |x-y|}{\text{ dt}}\\&\geq \frac{1}{\lambda} \rho(x) e^{-\epsilon_0 9L} |x-y|.\end{align*}
It follows that in this case,
 \begin{align*}l_\rho(\alpha) \leq 2\lambda^2 e^{\epsilon_0 27L} l_\rho(\gamma).\end{align*}
Thus with the choice of
 $\epsilon_0 $
as in (3·13), we see that, in this case we can choose the constant
 $K= 6\lambda^2$
.
Now, if
 $|x-y|\geq 9L$
, then choose points
 $x=x_1, x_2,...,x_n, x_{n+1}=y, n\geq 2$
on the curve
 $\alpha$
such that
 $l\left(\alpha[x_k, x_{k+1}]\right)= 9L$
and
 $l\left(\alpha[x_n, x_{n+1}]\right)\lt 9L.$
Let
 $\alpha_k= \alpha[x_k, x_{k+1}]$
.
We claim that
 $B(x_k, 4L)\cap B(x_m, 4L)=\emptyset$
for
 $1\leq k\lt m \leq n$
. If this is not the case, then for
 $z\in B(x_k, 4L)\cap B(x_m, 4L)$
, we obtain on one hand
 \begin{align*}|x_k-x_m| \leq |x_k-z|+|x_m-z|\lt 8L,\end{align*}
and on the other hand,
 \begin{align*}|x_k-x_m|\geq l\left(\alpha[x_k, x_m]\right)-h \geq 9L -h \gt 8L,\end{align*}
which is the desired contradiction, and thus the claim holds.
By (3·15),
 $\gamma$
intersects the balls
 $B(x_k,3L)$
for every k, and since
 $n\geq 2$
,
 $\gamma$
cannot be entirely within
 $B(x_k, 4L)$
for any k. Consequently, there exists a subcurve
 $\gamma_k$
of
 $\gamma$
contained in
 $\bar{B}(x_k, 4L)\setminus B(x_k, 3L)$
connecting
 $B(x_k, 3L)$
to
 $X\setminus B(x_k, 4L)$
for
 $1\leq k \leq n$
. Additionally, these subcurves are mutually disjoint because the family
 $\left\{B(x_k, 4L), 1\leq k \leq n\right\}$
is. Therefore,
 \begin{align*}l_\rho(\gamma)\geq \sum_{k=1}^n l_\rho \left(\gamma_k\right).\end{align*}
Now, for
 $1\leq k\leq n$
we have,
 \begin{align*}l_\rho(\gamma_k) &= \int_{\gamma_k} \rho {\text{ ds}} \geq \int_{\gamma_k}\frac{1}{\lambda}\rho(x_k) e^{-\epsilon |x_k-\gamma_k(t)|}{\text{ dt}}\\&\geq \int_{\gamma_k}\frac{1}{\lambda}\rho(x_k)e^{-\epsilon_0 4L}{\text{ dt}}\\&\geq \frac{1}{\lambda}\rho(x_k)e^{-\epsilon_0 4L} L\end{align*}
and
 \begin{align*}l_\rho(\alpha_k) &= \int_{\alpha_k} \rho {\text{ ds}} \leq \int_{\alpha_k} \lambda\rho(x_k) e^{\epsilon |x_k-\alpha_k(t)|}{\text{ dt}}\\&\leq \int_{\alpha_k} \lambda\rho(x_k) e^{\epsilon_0 9L}{\text{ dt}}\\&\leq \lambda\rho(x_k) e^{\epsilon_0 9L}9L.\end{align*}
Therefore,
 \begin{align*}l_\rho(\alpha) = \sum_{k=1}^n l_\rho(\alpha_k) \leq \sum_{k=1}^n\lambda\rho(x_k) e^{\epsilon_0 9L}9L \leq 9\lambda^2 e^{\epsilon_0 13L}\sum_{k=1}^nl_\rho(\gamma_k)\leq 9\lambda^2 e^{\epsilon_0 13L} l_\rho(\gamma). \end{align*}
A simple estimation shows that here you can take the constant
 $K=18\lambda^2$
. Hence the proof of the Theorem 1·5 is complete.
4. Uniformisation
Before proving that the deformed spaces are indeed uniform, we need the following two crucial lemmas.
Lemma 4·1. Let X be an intrinsic
 $\delta$
-hyperbolic space. Let
 $\gamma\;:\;x\;{\curvearrowright}\; y$
be an h-short arc in the metric space X and
 $p\in X$
be fixed. Let
 $x_\gamma, y_\gamma\in \gamma$
be points in the curve
 $\gamma$
such that
 $l\left(\gamma[x, x_\gamma] \right)= (y|p)_x$
and
 $l\left(\gamma[y_\gamma, y] \right)= (x|p)_y$
. If
 $z\in \gamma[x, y_\gamma]$
and
 $u\in \gamma[x, z]$
, then
 \begin{align*}|p-u|-|p-z|\geq |u-z|-8\delta-8h.\end{align*}
Proof. Construct an h-short triangle
 $\Delta$
with sides
 $\alpha, \beta, $
and
 $\gamma$
, where
 $\alpha\;:\;x\;{\curvearrowright}\; p$
and
 $\beta \;:\; y\;{\curvearrowright}\; p$
. We follow the notations as in Definition 2·6. First, suppose that
 $z\in \gamma_x$
and
 $u\in \gamma[x, z]$
. Then, there exist points
 $z', u'\in \alpha_x$
such that
 $l\left(\alpha[x, z']\right) = l\left(\gamma[x,z]\right)$
and
 $l\left(\alpha[x, u']\right) = l\left(\gamma[x, u]\right).$
Hence, by the Tripod Lemma, we have 2.5
 $|z-z'|\leq 4\delta+2h$
and
 $|u-u'|\leq 4\delta +2h$
.
Now, we compute,
 \begin{align*}|p-u|-|p-z| &\geq |p-u'|-|u-u'|-|p-z'|-|z-z'| \\&\geq l\left(\alpha[u', p]\right)-h -l\left(\alpha[z', p]\right)-8\delta-4h\\&=l\left(\alpha[u', z']\right)-8\delta-5h\\&=l\left(\alpha[u, z]\right)-8\delta-5h\\&\geq |u-z|-8\delta-5h.\end{align*}
Now, if
 $z\in \gamma[x_\gamma, y_\gamma]$
and
 $u\in \gamma[x, x_\gamma]$
, then there exists
 $u'\in \alpha[x, x_\alpha]$
such that
 \begin{align*}|u-u'|\leq 4\delta +2h.\end{align*}
We observe that,
 \begin{align*}l\left(\gamma[x, u]\right)+l\left(\gamma[u,x_\gamma]\right) &= l\left(\gamma[x, x_\gamma]\right) = l\left(\alpha[x, x_\alpha]\right) \leq |x-x_\alpha|+h\leq l\left(\alpha[x, u']\right)\\ &\quad +|u'-x_\alpha|+h\end{align*}
which implies that
 \begin{equation} l\left(\gamma[u,x_\gamma]\right) \leq l\left(\alpha[u', x_\alpha]\right)+h.\end{equation}
Thus,
 \begin{align*}|p-u|-|p-z|&\geq |p-u'|-|u-u'|-|p-x_\alpha|-|x_\alpha - z|\\&\geq l\left(\alpha[u', p]\right)-h-l\left(\alpha[x_\alpha, p]\right)-|x_\alpha -z|-4\delta-2h\\&\geq l\left(\gamma[u,x_\gamma]\right) -|x_\alpha -x_\gamma|-|x_\gamma-z|-4\delta-4h\\&\geq l\left(\gamma[u, z]\right)- l\left(\gamma[x_\gamma, z]\right)-8\delta-8h\\&\geq |u-z|-8\delta-8h,\end{align*}
where we used (4·1) in the third step.
Finally we consider the case where
 $u, z\in \gamma[x_\gamma, y_\gamma]$
and compute
 \begin{align*}|p-u|-|p-z| &\geq |p-x_\alpha|-|x_\alpha - u|- |p-p_\alpha|-|p_\alpha -z|\\&\geq l\left(\alpha[p, x_\alpha]\right) -h - l\left(\alpha[p, x_\alpha]\right) -|x_\alpha-u| -|p_\alpha -z|\\&\geq -8\delta-7h\\&\geq |u-z|-8\delta-8h,\end{align*}
where in the last step we used the fact that
 $|u-z|\leq h$
.
Lemma 4·2. Let X be an intrinsic
 $\delta$
-hyperbolic space and let
 $x, y\in X$
,
 $\omega\in \partial_\infty X$
. If
 $\gamma \;:\; x\;{\curvearrowright}\; y $
is any h-short arc and
 $b=b_{\omega, o} \in \mathcal{B}(\omega)$
, then
 \begin{align*}b(u)-b(z) \geq |u-z|-16\delta-10h, \text{ for any }z\in \gamma[x, y'] \text{ and for all } u \in \gamma[x, z],\end{align*}
where
 $y' \in \gamma $
is such that
 $l(\gamma[y', y]) = (x|\omega)_y$
.
Proof. Let
 $x'\in \gamma $
be such that
 $l(\gamma[x, x']) = (y|\omega)_x$
, then it follows from Lemma 2·4 that
 \begin{align*}l(\gamma[x, x'])+ l(\gamma[y', y]) = (y|\omega)_x + (x|\omega)_y \leq |x-y| \leq l(\gamma),\end{align*}
which implies that
 $x'\in \gamma[x, y']$
.
Moreover, by Lemma 2·4 we obtain
 \begin{align*}l(\gamma[x', y']) \leq l(\gamma)-(x|\omega)_y-(y|\omega)_x \leq |x-y|+h -(x|\omega)_y-(y|\omega)_x \leq 2\delta +h, \end{align*}
which yields us
 \begin{align*}|x'-y'|\leq 2\delta +h.\end{align*}
Let
 $\bar{\alpha} \;:\; x\;{\curvearrowright}\; \omega $
be a
 $(4\delta+2h, h)$
-road. Write
 $\alpha_n\;:\;x\;{\curvearrowright}\; u_n$
, then it is known that the sequence
 $\{u_n\}\in \omega$
. Now, pick points
 $x_n, y_n\in \gamma$
satisfying
 $l(\gamma[x, x_n]) = (y|u_n)_x$
and
 $l(\gamma[y_n, y]) = (x|u_n)_y$
. Further, for each
 $r\gt 0$
, by virtue of Lemma 2·4, we have
 \begin{equation} l(\gamma[x, x']) = (y|\omega)_x \leq (y|u_n)_x +r = l(\gamma[x, x_n]) +r\end{equation}
and
 \begin{equation} l(\gamma[y', y]) =(x|\omega)_y \leq (x|u_n)_y +r = l(\gamma[y_n, y]) +r\end{equation}
for sufficiently large n. Let
 $x'',y''\in\gamma $
be such that
 $l(\gamma[x, x'']) = (y|\omega)_x -r = l(\gamma[x, x']) - r$
and
 $l(\gamma[y'', y]) =(x|\omega)_y -r = l(\gamma[y', y])-r$
, provided both
 $(y|\omega)_x -r$
and
 $(x|\omega)_y -r$
are non-negative numbers, otherwise we let
 $x''=x$
and
 $y''=y$
. Hence, it follows from (4·2), (4·3), and the fact that
 $x_n\in \gamma[x, y_n]$
that
 $x_n, y_n \in \gamma[x'', y'']$
. Furthermore, we observe that
 $l(\gamma[x'', y''])= 2r+l(\gamma[x', y'])\leq 2r+2\delta+h$
.
We claim that
 \begin{equation} |u_n-u|-|u_n-z| \geq |u-z|-2r-12\delta-10h.\end{equation}
We consider three cases:
Case 1. Assume that
 $z\in \gamma[x, y_n]$
, then for
 $u\in \gamma[x, z]$
by Lemma 4·1 we have
 \begin{align*}|u_n-u|-|u_n-z|\geq |u-z|-8\delta-8h.\end{align*}
Case 2. If
 $z, u \in \gamma[y_n, y']$
, then
 $|u-z| \leq l(\gamma[x'', y''])\leq 2r+2\delta+h.$
Therefore, we obtain,
 \begin{align*}|u_n-u|-|u_n-z|\geq -|u-z| \geq |u-z|-4\delta-2h-2r.\end{align*}
Case 3. Suppose that
 $z\in \gamma[y_n, y']$
and
 $u\in \gamma[x, y_n]$
and by case 1, we have
 $|u_n-u| -|u_n-y_n| \geq |u-y_n|-8\delta -8h$
. Then, we compute
 \begin{align*}|u_n-u|-|u_n-z| &\geq |u_n-u| -|u_n-y_n|-|y_n-z|\\&\geq |u-y_n|-|y_n-z|-8\delta -8h\\&\geq |u-z|-2|y_n-z|-8\delta -8h\\&\geq |u-z|-2r-12\delta-10h.\end{align*}
Hence, our claim is true and the lemma follows from (2·6).
Lemma 4·3. Let
 $x, y\in X$
and
 $\gamma \;:\; x\;{\curvearrowright}\; y $
be an h-short arc, satisfying
 $l(\gamma) \leq 2|x-y|$
. Then there exists a constant
 $C=C(\delta, \epsilon, h)$
such that
 \begin{equation} l_\epsilon(\gamma) \asymp_C e^{-\epsilon(x|y)_b} \min \left\{\frac{1}{2}, \epsilon|x-y|\right\}.\end{equation}
Proof. Let
 $\gamma \;:\; x\;{\curvearrowright}\; y$
be an h-short arc satisfying
 $l(\gamma) \leq 2|x-y|$
. Further, let
 $y'\in \gamma$
be such that
 $l(\gamma[y', y])=(x|\omega)_y$
. Then, by Lemma 4·2 and from (2·5), we have
 \begin{align*} |x-y'|-16\delta-10h \leq b(x)-b(y')\leq |x-y'|+10\delta\end{align*}
and by symmetry we have
 \begin{align*}|y-y'|-16\delta-10h \leq b(y)-b(y')\leq |y-y'|+10\delta ,\end{align*}
which yields us
 \begin{align*}|x-y'|+|y-y'|-32\delta-20h \leq b(x)+b(y)-2b(y') \leq |x-y'|+|y-y'|+20\delta.\end{align*}
Thus, a simple computation gives us
 \begin{align*}|x-y|-32\delta-23h \leq b(x)+b(y)-2b(y') \leq |x-y| +20\delta +h,\end{align*}
which implies that
 \begin{align*}-16\delta-\frac{23}{2}h \leq (x|y)_b-b(y')\leq 10\delta+\frac{h}{2}.\end{align*}
Thus we obtain,
 \begin{equation} b(y')\dot{=}_{16\delta+12h} (x|y)_b.\end{equation}
Hence, it suffices to show that there exists
 $C'=C'(\delta, \epsilon, h)$
such that
 \begin{equation} l_\epsilon(\gamma) \asymp_{C'} \rho_\epsilon(y') \min \left\{\frac{1}{2}, \epsilon|x-y|\right\}.\end{equation}
If
 $\epsilon |x-y| \leq 1/2$
, then for all
 $u\in \gamma$
, we have
 \begin{align*}e^{\epsilon |u-y'|}\leq e^{\epsilon l(\gamma [u, y'])} \leq e^{\epsilon l(\gamma)} \leq e.\end{align*}
Together with (2·7), we obtain
 \begin{equation}\frac{1}{e^{10\epsilon\delta +1} } \rho_\epsilon(y')\leq \frac{e^{-\epsilon |u-y'|}}{e^{10\epsilon\delta}} \rho_\epsilon(y') \leq \rho_\epsilon(u) \leq e^{10\epsilon\delta} e^{\epsilon |u-y'|} \rho_\epsilon(y') \leq e^{10\epsilon\delta +1} \rho_\epsilon(y').\end{equation}
Therefore, on one hand we have
 \begin{align*}l_\epsilon (\gamma)= \int_\gamma \rho_\epsilon(u) |du| \leq 2 e^{10\epsilon\delta +1} \rho_\epsilon(y')|x-y| \end{align*}
and on the other hand, we have
 \begin{align*}l_\epsilon(\gamma) = \int_\gamma \rho_\epsilon |du| \geq \frac{\rho_\epsilon(y')}{ e^{10\epsilon \delta +1}} |x-y|.\end{align*}
Now, if
 $\epsilon |x-y| \gt 1/2$
, then by Lemma 4·2 for every
 $u\in \gamma$
, we have
 \begin{align*}e^{-\epsilon b(u) } \leq e^{-\epsilon b(y')}e^{-\epsilon |u-y'|} e^{\epsilon 16\delta+\epsilon 10h},\end{align*}
which gives us
 \begin{align*}\rho_\epsilon(u) \leq e^{\epsilon 16\delta+\epsilon 10h} \rho_\epsilon(y') e^{-\epsilon |u-y'|}.\end{align*}
Thus, a simple computation shows that
 \begin{align*}l_\epsilon(\gamma) &= \int_\gamma \rho_\epsilon (u) |du| \\&\leq e^{\epsilon 16\delta+\epsilon 10h} \rho_\epsilon(y') \int_\gamma e^{-\epsilon |u-y'|}|du|\\&\leq e^{\epsilon 16\delta+\epsilon 10h} \rho_\epsilon(y')\left[ \int_{\gamma[x, y']} e^{-\epsilon l(\gamma[u, y'])+\epsilon h}|du| + \int_{\gamma[y', y] } e^{-\epsilon l(\gamma[u, y'])+\epsilon h}|du| \right]\\&\leq 2e^{\epsilon 16\delta+\epsilon 11h} \rho_\epsilon(y') \int_0^\infty e^{-\epsilon t} dt\\&\leq 2\epsilon^{-1} e^{\epsilon 16\delta+\epsilon 11h} \rho_\epsilon(y'),\end{align*}
which gives the upper bound in (4·7) when
 $|x-y|\gt 1/2$
. For the lower bound of (4·7), in view of (2·5), we find that
 \begin{align*}b(u)\leq b(y') +|u-y'|+10\delta\end{align*}
for all
 $u\in \gamma$
, which ensures that
 $\rho_\epsilon(u)\geq \rho_\epsilon(y') e^{-\epsilon |u-y'|} e^{- 10 \epsilon \delta}$
. Therefore,
 \begin{align*}l_\epsilon(\gamma) &= \int_{\gamma} \rho_\epsilon(u) |du|\\&\geq \rho_\epsilon(y')e^{- 10 \epsilon \delta} \int_\gamma e^{-\epsilon |u-y'|} |du|\\& \geq \rho_\epsilon(y')e^{- 10 \epsilon \delta} \left[ \int_{\gamma[x, y']} e^{-\epsilon l(\gamma[u, y'])}|du| + \int_{\gamma[y', y] } e^{-\epsilon l(\gamma[u, y'])}|du| \right]\\&\geq \rho_\epsilon(y')e^{- 10 \epsilon \delta} \int_0^{|x-y|/2} e^{-\epsilon t} dt \\&\geq \rho_\epsilon(y')e^{- 10 \epsilon \delta} \frac{1}{\epsilon} (1-e^{-1/4}) \\&\geq \frac{1}{2} \rho_\epsilon(y')e^{- 10 \epsilon \delta} \frac{1}{\epsilon}.\end{align*}
This completes the proof.
Corollary 4·4. There exists a constant
 $M=M(\delta, \epsilon)$
such that
 \begin{equation} d_\epsilon (x, y) \asymp_M e^{-\epsilon(x|y)_b} \min \left\{1/2, \epsilon|x-y|\right\} \text{ for all } x,y\in X.\end{equation}
Proof. The upper bound follows easily from (4·5). For the lower bound, take
 $h=1/14$
and choose an h-short arc
 $\gamma \;:\;x\;{\curvearrowright}\; y$
satisfying
 $l(\gamma)\leq 2|x-y|$
. Then by Theorem 1·5, we have
 \begin{align*}l_\epsilon(\gamma) \leq K(\delta) d_\epsilon(x, y).\end{align*}
Combining this with the lower bound for
 $l_\epsilon(\gamma)$
in Lemma 4·3, we get the desired result.
Proof of Theorem
1·6. Let X be an intrinsic
 $\delta$
-hyperbolic space with at least two elements in the boundary
 $\partial_\infty X$
. We equip X with the metric defined as in (1·4) and we intend to prove that the space
 $X_\epsilon=(X, d_\epsilon)$
are unbounded uniform spaces.
Our first aim is to prove that
 $X_\epsilon$
is a rectifiably connected metric space. To this end, we show that the identity map
 $\left(X, |x-y|\right)\rightarrow \left(X, d_\epsilon\right)$
is locally bilipschitz. Let
 $w\in X$
be fixed and consider the open ball B(w, 1). Then, for every
 $z\in B(w, 1)$
, by virtue of (2·7), we obtain
 \begin{align*}e^{-\epsilon-10\epsilon\delta}\rho_\epsilon (w)\leq \rho_\epsilon (z) \leq e^{\epsilon+10\epsilon\delta}\rho_\epsilon(w).\end{align*}
Now, for
 $x, y\in B(w, 1)$
, choose an
 $\alpha$
in X joining them satisfying
 $l(\gamma)\leq 2|x-y|$
, then for any
 $u\in \alpha$
we have by (2·7) that,
 \begin{align*}\rho_\epsilon(u) \leq e^{10\epsilon\delta}e^{\epsilon|x-u|}\rho_\epsilon(x)\leq e^{10\epsilon\delta}e^{4\epsilon}\rho_\epsilon(x) \leq e^{5\epsilon+20\epsilon\delta} \rho_\epsilon (w).\end{align*}
Thus, for
 $x, y\in B(w, 1)$
, this implies that,
 \begin{align*}d_\epsilon(x, y) \leq \int_\alpha \rho_\epsilon {\text{ ds}} \leq 2e^{5\epsilon+20\epsilon\delta}\rho_\epsilon(w)|x-y| . \end{align*}
Now, for any curve
 $\gamma$
joining x and y we can find a subcurve
 $\gamma'$
of
 $\gamma$
emanating from x such that
 $l(\gamma')=|x-y|$
. Therefore, by (2·7) one computes,
 \begin{align*}d_\epsilon(x, y) &= \inf_\gamma\int_\gamma \rho_\epsilon {\text{ ds}} \geq \inf_\gamma\int_{\gamma'} \rho_\epsilon {\text{ ds}}\\&\geq \int_0^{|x-y|}\rho_\epsilon(x) e^{-10\epsilon \delta} e^{-\epsilon t}{\text{ dt}}\\&\geq \rho_\epsilon(x) e^{-10\epsilon \delta-2\epsilon}|x-y|\\&\geq e^{-20\epsilon\delta-3\epsilon}\rho_\epsilon(w)|x-y| .\end{align*}
Hence, we see that the identity map is locally bilipschitz and thus
 $X_\epsilon$
is a rectifiably connected metric space.
We next verify that
 $X_\epsilon$
is unbounded. For
 $h\lt 1/13$
, choose h-short arcs
 $\alpha_i\;:\;o\;{\curvearrowright}\; u_i$
satisfying
 $l(\alpha_i)\leq 2|o-u_i|$
, where the sequence
 $\{u_i\}\in \omega$
. By Lemma 2·4, we may assume that for any
 $x\in X$
and for sufficiently large n, we have
 \begin{align*}(\omega|o)_x \leq (u_n|o)_x+\frac{1}{2}\end{align*}
and
 \begin{align*}(\omega|x)_o \geq (u_n|x)_o-\delta-\frac{1}{2}.\end{align*}
Therefore, for
 $b=b_{\omega, o}\in \mathcal{B}(\omega)$
and for sufficiently large n, we obtain,
 \begin{align*}b(x) = (\omega|o)_x-(\omega|x)_o \leq (u_n|o)_x-(u_n|x)_o+\delta+1= |u_n-x|-|u_n-o|+\delta+1.\end{align*}
In particular, for
 $x=\alpha_n(t)$
, we have
 \begin{align*}b(\alpha_n(t))\leq |u_n-\alpha_n(t)|-|u_n-o|+\delta+1\leq h+\delta +1\end{align*}
for sufficiently large n. Now, by combining this with Theorem 1·5, we obtain,
 \begin{align*}d_\epsilon(0, u_n)\geq \frac{1}{M} l_\epsilon(\alpha_n) \geq \frac{1}{M} \int_{\alpha_n}e^{-\epsilon(\delta+h+1)}{\text{ dt}} \geq \frac{1}{M}e^{-\epsilon(\delta+2)}|o-u_n|\end{align*}
for sufficiently large n. Since,
 $|o-u_n|{\rightarrow} \infty $
as
 $n{\rightarrow} \infty$
, we obtain that
 $X_\epsilon$
is unbounded.
Next we prove that
 $X_\epsilon$
is incomplete as long as there exists
 $\zeta\neq \omega$
such that
 $\zeta\in \partial_\infty X$
. Let
 $\{u_n\}\in \zeta $
, we prove that
 $\{u_n\} $
is a Cauchy sequence in
 $X_\epsilon$
. From (2·8) we have
 \begin{align*}(u_n|u_m)_b \dot{=} (u_n|u_m)_o -(u_n|\omega)_o -(u_m|\omega)_o.\end{align*}
Since
 $\{u_n\}\in \zeta \neq \omega$
, it follows that
 $(u_k|\omega)_o \lt \infty $
for every
 $k\in \mathbb{N}$
. Therefore, we see that
 $(u_n|u_m)_b \rightarrow \infty $
as
 $n, m \rightarrow \infty$
. Let
 $\gamma \;:\; u_n \;{\curvearrowright}\; u_m $
be any h-short arc with
 $h\lt 1/13$
satisfying
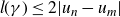 $l(\gamma) \leq 2|u_n-u_m|$
. Further, without loss of generality we assume that
 $\epsilon|u_n-u_m| \geq 1/2$
. Then, by Lemma 4·3, we obtain that
 \begin{align*}d_\epsilon(u_n, u_m ) \leq l_\epsilon(\gamma) \leq \frac{C}{2} e^{-\epsilon (x|y)_b } \rightarrow 0 \text{ as } n, m\rightarrow \infty .\end{align*}
Thus,
 $\{u_n\}$
is a Cauchy sequence in
 $(X_\epsilon, d_\epsilon)$
. Since,
 $\{u_n\}$
is a Gromov sequence in X, and X is locally bilipschitz equivalent to
 $X_\epsilon$
, the sequence
 $\{u_n\}$
cannot converge to a point inside
 $X_\epsilon$
. Therefore,
 $X_\epsilon$
is incomplete and, consequently its metric boundary
 $\partial_\epsilon X \;:\!=\; \overline{X_\epsilon}\setminus X_\epsilon$
is non-empty.
Using Harnack inequality, for all
 $x, y\in X$
satisfying
 $|x-y|\gt 1/\epsilon$
, we calculate
 \begin{align*}d_\epsilon(x, y) &= \inf \int_\gamma \rho_\epsilon {\text{ ds}}\\&\geq \int_0^{1/\epsilon} e^{-10\epsilon\delta} \rho_\epsilon(x) e^{-\epsilon t}{\text{ dt}}\\&= \epsilon^{-1} e^{-10\epsilon\delta} \rho_\epsilon(x) \left(1-e^{-1}\right)\\&\geq \epsilon^{-1} e^{-10\epsilon\delta -1} \rho_\epsilon(x).\end{align*}
For any
 $x\in X$
, we define
 \[d_\epsilon(x) \;:\!= {\text{dist}}_\epsilon (x, \partial_\epsilon X) = \inf \{d_\epsilon(x, z) \;:\; z\in \partial_\epsilon X\}.\]
Observe that,
 \begin{equation} d_\epsilon(x) \geq \frac{\rho_\epsilon(x)}{\epsilon e^{10\epsilon\delta +1}}.\end{equation}
It remains to prove that
 $X_\epsilon$
is uniform. Since, X is intrinsic, any two points
 $x, y\in X$
can be joined by an h-short arc
 $\gamma$
satisfying
 $l(\gamma)\leq 2|x-y|$
, where
 $0\leq h \lt 1/13.$
Therefore, by Theorem 1·5, we observe that the quasiconvexity condition is satisfied. Thus, we need only verify the double cone arc condition for the curve
 $\gamma$
. By symmetry it suffices to prove the cone condition for all
 $z\in \gamma[z, y']$
where
 $y' \in \gamma $
is such that
 $l(\gamma[y', y]) = (x|\omega)_y$
.
To this end, by Lemma 4·2 we have
 \begin{align*}b(u) \geq b(z)+ |u-z|-16\delta-10h, \text{ for all } u \in \gamma[x, z].\end{align*}
Thus,
 \begin{align*} l_\epsilon(\gamma) &= \int_\gamma \rho_\epsilon(u) |du|\\ &= \int_\gamma e^{-\epsilon b(u)} |du|\\ & \leq \int_\gamma \exp\left\{-\epsilon\left[ b(z)+ |u-z|-16\delta-10h\right]\right\}|du|\\ &\leq \rho_\epsilon(z) \exp \left\{\epsilon\left[16\delta+10h\right]\right\} \int_\gamma e^{-\epsilon|u-z|} |du|\\ &\leq \rho_\epsilon(z) \exp \left\{\epsilon\left[16\delta+11h\right]\right\}\int_0^\infty e^{-\epsilon t} dt\\ &\leq \exp \left\{\epsilon\left[26\delta+11h\right]+1\right\} d_\epsilon(z), \end{align*}
where in the last step we used (4·10). This completes the proof of the Theorem 1·6.
Proof of Theorem
1·7. We define a map
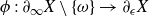 $\phi \;:\; \partial_\infty X \setminus \{\omega\} \rightarrow \partial_\epsilon X $
as follows. For every
 $\zeta \neq \omega $
in
 $\partial_\infty X $
, let
 $\{v_n\} \in \zeta $
then by the proof of incompleteness in Theorem 1·6, we see that
 $\{v_n\}$
is a
 $d_\epsilon$
Cauchy sequence which converges to a limit on
 $\partial_\epsilon X$
. We define
 $\phi(\zeta) $
as the limit of this Cauchy sequence in
 $\partial_\epsilon X$
.
Let
 $\{u_n\}, \{u_n'\} \in \eta \neq \omega$
, then an application of (4·5) shows that they are equivalent Cauchy sequences in the space
 $(X_\epsilon, d_\epsilon)$
. Therefore, the map
 $\phi$
is well defined.
Secondly, we show that
 $\phi $
is injective. If for
 $\zeta , \eta \in \partial_\infty X \setminus \{\omega\}$
we have
 $\phi(\zeta) = \phi (\eta)$
, then for any Gromov sequences
 $\{u_n\}\in \zeta$
and
 $\{v_n\} \in \eta $
, we obtain that
 \begin{align*}d_\epsilon (u_n, v_n ) \rightarrow \infty \text{ as } n\rightarrow \infty.\end{align*}
Moreover, if
 $\epsilon |u_n-v_n| \leq 1/2$
, we have
 \begin{align*}2(u_n|v_n)_o \geq (u_n|v_n)_o - |u_n-v_n| \rightarrow \infty \text{ as } n\rightarrow \infty,\end{align*}
which shows that
 $\{u_n\}$
and
 $\{v_n\}$
are equivalent Gromov sequences and hence
 $\zeta = \eta$
. If
 $\epsilon |u_n-v_n| \gt 1/2$
, then by Lemmas 4.3, 1.5 and from (2·8) we conclude that
 \begin{align*}(u_n|v_n)_o - (u_n|\omega)_o - (\omega|v_n)_o \dot{=} (u_n|v_n)_b \rightarrow \infty \text{ as } n\rightarrow \infty,\end{align*}
which implies that
 $(u_n|v_n)_o \rightarrow \infty$
and therefore
 $\zeta = \eta$
. Hence,
 $\phi $
is injective.
Let
 $a\in \partial_\epsilon X$
and let
 $\{a_n\} $
be a
 $d_\epsilon$
-Cauchy sequence which converges to a. We prove that
 $\{a_n\} $
is a Gromov sequence in X. Observe that
 $\{a_n\} $
cannot be Cauchy in X, because if it is indeed a Cauchy sequence then
 $\{a_n\} $
converges to some point in X. But since X and
 $X_\epsilon$
are locally bilipchitz equivalent this would imply that
 $\{a_n\} $
is
 $d_\epsilon$
convergent to some point in
 $X_\epsilon$
, which is a contradiction. Therefore, from Corollary 4·4, we see that
 $(a_n|a_m)_b \rightarrow \infty $
as
 $n, m\rightarrow \infty$
. Again, by (2·8), we obtain
 \begin{align*}(a_n|a_m)_o - (a_n|\omega)_o- (\omega|a_m)_o \dot{=} (a_n|a_m)_b \rightarrow \infty \text{ as } n, m \rightarrow \infty ,\end{align*}
which guarantees us that
 $(a_n|a_m)_o \rightarrow \infty$
. Hence,
 $\{a_n\} $
is a Gromov sequence in X, and it is clear by the definition of
 $\phi$
that a is the image under
 $\phi$
of the Gromov boundary element represented by
 $\{a_n\} $
. Thus
 $\phi$
is surjective. This completes the proof.
Acknowledgement
The authors thank the anonymous referee for the insightful comments, which significantly improved the clarity of the manuscript. The first named author thanks SERB-CRG and the second named author’s research work is supported by CSIR-UGC.



