



1 Introduction
Leading-edge vortices (LEVs) can be formed by rotating wings or plates at high angles of incidence (Bross, Ozen & Rockwell Reference Bross, Ozen and Rockwell2013; Garmann & Visbal Reference Garmann and Visbal2014; Wojcik & Buchholz Reference Wojcik and Buchholz2014). These flows are often characterized by helical flow about a coherent vortex core above the suction side of the wing, with a span-wise flow component directed away from the centre of rotation (CoR). This flow pattern is depicted in figure 1, and has been clearly demonstrated in previous literature (see for example the bubble visualizations completed by Lentink & Dickinson (Reference Lentink and Dickinson2009), or the particle tracking flow visualizations from the simulations of Harbig, Sheridan & Thompson (Reference Harbig, Sheridan and Thompson2013)).
Sketch of a stable LEV trajectory over a steadily rotating plate. The steady, axial streamline aligned with the LEV core is depicted, as well as the spiralling flow in the vicinity of the vortex core. The Cartesian coordinate system for the analysis to follow is fixed to the axis of rotation as shown.

LEVs are an important force-enhancing flow feature in the flight of insects (Usherwood & Ellington Reference Usherwood and Ellington2002; Lentink & Dickinson Reference Lentink and Dickinson2009), permitting these organisms to support greater body and cargo weights than would be possible by employing the steady, attached-flow mechanisms of conventional aerodynamics (Ellington et al. Reference Ellington, van den Berg, Willmott and Thomas1996). Some aquatic organisms have also been shown to generate LEVs during locomotion at similar Reynolds numbers to their airborne counterparts (Borazjani & Daghooghi Reference Borazjani and Daghooghi2013; Murphy et al. Reference Murphy, Adhikari, Webster and Yen2016). Accordingly, the exploitation of LEVs has garnered interest for applications such as micro-aerial vehicles and autonomous underwater vehicles. The formation of LEVs near the hub of small wind turbines, which often lack pitch adjustment, also plays an important role in turbine starting (Wood Reference Wood2011). In the present study, a focus on LEVs over steadily rotating wings is maintained, as is observed in the autorotation of some tree seeds (Lentink et al. Reference Lentink, Dickson, van Leeuwen and Dickinson2009; Salcedo et al. Reference Salcedo, Treviño, Vargas and Martínez-Suástegui2013; Lee, Lee & Sohn Reference Lee, Lee and Sohn2014). Herein, an LEV is referred to as stable if its core maintains a mean convection speed of zero relative to a steadily rotating plate.
In order to predict the performance of rotors in separated flows, knowledge of the span-wise extent of a stable LEV, and the associated force-enhancement, is critical. Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015) considered this problem experimentally using particle image velocimetry (PIV) to investigate the flow field over rotating plates of varying aspect ratio. As the aspect ratio was increased to ten, it was observed that a stable LEV persists no farther than four chord lengths from CoR in the span-wise direction. Their PIV results show that the wake, as viewed on span-normal planes, transitions from thin to thick as one moves outboard from the CoR. The transition to a thick wake was also accompanied by greater temporal variance in local velocities, and they attributed this unsteadiness to vortex shedding.
In the present work, it is suggested that stable LEVs are only observed near the CoR due to the tilting of the LEV away from the leading edge. It is hypothesized that the pseudo-forces associated with the rotating frame of reference, i.e. centrifugal and Coriolis forces, are significant and possibly dominant in driving this tilting process. This represents an alternative role for Coriolis acceleration to the stabilizing or destabilizing effects that have been discussed in previous literature (e.g. Lentink & Dickinson Reference Lentink and Dickinson2009; Garmann & Visbal Reference Garmann and Visbal2014). A simplified model is developed in § 2 to predict the steady-state trajectory of a stable LEV core under the influence of the pseudo-forces. In order to validate our hypothesis, the predicted LEV trajectory is compared to the estimated vortex core locations on various span-normal planes in the work of Garmann & Visbal (Reference Garmann and Visbal2014), and to the observed trajectory of the LEV axis and nearby streamlines in the work of Phillips, Knowles & Bomphrey (Reference Phillips, Knowles and Bomphrey2015). A separate solution to the presented model is obtained for direct comparison to each of these studies.
2 Model derivation
Two fundamental assumptions form the basis of the LEV trajectory model: (i) the vortex core location is stationary relative to the body, and (ii) there exists uni-directional axial flow through the LEV core directed away from the CoR. Due to the second assumption, the model will only be valid in regions inboard of vortex breakdown, which generates flow reversal in the vortex core, e.g. Sarpkaya (Reference Sarpkaya1971). That said, when these two conditions are satisfied, an axial streamline aligned with the LEV core trajectory must exist (see figure 1). It is the trajectory of such a streamline that the presented model will predict.
The Navier–Stokes equations are cast in streamline coordinates on an axial streamline through the LEV core. The defined polar coordinate system, which lies in the
 $xy$
-plane, allows the predicted trajectory of the axial streamline to be expressed in the form
 ${\it\sigma}={\it\sigma}({\it\theta})$
.

The Navier–Stokes equations are cast in the rotating frame of reference onto this axial streamline through the LEV core, as done by Fay (Reference Fay1994) for the Euler equations. Figure 2 depicts the streamline-fixed coordinate system. Consider first the streamline-normal direction, denoted by unit vector
 $\hat{\boldsymbol{n}}$
:
 $$\begin{eqnarray}{\it\rho}\frac{\text{D}u_{n}}{\text{D}t}=-\frac{\partial p}{\partial n}+{\it\mu}({\rm\nabla}^{2}\boldsymbol{u})\boldsymbol{\cdot }\hat{\boldsymbol{n}}+2{\it\rho}{\it\Omega}u_{s}+{\it\rho}{\it\Omega}^{2}\boldsymbol{r}\boldsymbol{\cdot }\hat{\boldsymbol{n}},\end{eqnarray}$$
where
 ${\it\rho}$
is density,
 ${\it\mu}$
is viscosity,
 $p$
is pressure,
 ${\it\Omega}$
is the constant angular velocity of the plate,
 $\boldsymbol{u}$
is the velocity vector, and
 $u_{n}$
and
 $u_{s}$
are streamline-normal and -aligned components of velocity, respectively. By construction,
 $u_{n}$
is always zero, but its material derivative does not necessarily vanish.
 $\boldsymbol{r}$
is the radial vector from the CoR, which lies in a plane normal to the rotation vector. In accordance with the stated hypothesis, it is postulated that the pseudo-forces dominate this equation, and by comparison, the pressure gradient and viscous terms tend to zero. These simplifications can be justified physically, since the vortex core tends to be a local pressure minimum, and can be expected to lie at or near an inflection point of velocity (where the second spatial derivatives of velocity tend to zero). The
 $\hat{\boldsymbol{n}}$
-momentum equation thus reduces to
 $$\begin{eqnarray}\frac{\text{D}u_{n}}{\text{D}t}=2{\it\Omega}u_{s}+{\it\Omega}^{2}\boldsymbol{r}\boldsymbol{\cdot }\hat{\boldsymbol{n}}.\end{eqnarray}$$
Since the position of a stable LEV is stationary relative to the body, the material derivative can be related to the local curvature of the streamline,
 ${\it\kappa}$
, as given by
 $$\begin{eqnarray}\frac{\text{D}u_{n}}{\text{D}t}={\it\kappa}u_{s}^{2}.\end{eqnarray}$$
If one can designate a starting location of the LEV, i.e. the most inboard location of the stable LEV core, and the local curvature at all points along the axial streamline is known, then its trajectory is fully defined. This trajectory will be expressed in polar coordinates
 $({\it\sigma},{\it\theta})$
, as shown in figure 2. The origin of the polar coordinate system is offset from the CoR by
 ${\bf\sigma}_{0}$
to ensure that the radial coordinate
 ${\it\sigma}$
is a single-valued function of
 ${\it\theta}$
in the domain of interest. The curvature of the streamline can now be expressed in terms of
 ${\it\sigma}$
and
 ${\it\theta}$
(Gray, Abbena & Salamon Reference Gray, Abbena and Salamon2006):
 $$\begin{eqnarray}{\it\kappa}=\left[{\it\sigma}^{2}+2\left(\frac{\text{d}{\it\sigma}}{\text{d}{\it\theta}}\right)^{2}-{\it\sigma}\frac{\text{d}^{2}{\it\sigma}}{\text{d}{\it\theta}^{2}}\right]\left({\it\sigma}^{2}+\left(\frac{\text{d}{\it\sigma}}{\text{d}{\it\theta}}\right)^{2}\right)^{-3/2}.\end{eqnarray}$$
Finally, the dot product in the last term of (2.2) can be expressed in terms of
 ${\it\sigma}$
and its derivative
 ${\it\sigma}^{\prime }({\it\theta})$
. It can be readily shown that the angle
 ${\it\phi}$
between the vector
 ${\bf\sigma}$
and the unit vector
 $\hat{\boldsymbol{s}}$
is given by
 $$\begin{eqnarray}\tan {\it\phi}=\frac{{\it\sigma}}{{\it\sigma}^{\prime }({\it\theta})}.\end{eqnarray}$$
Combining the previous four equations and noting that
 $\boldsymbol{r}={\bf\sigma}+{\bf\sigma}_{0}$
, the following expression is obtained after algebraic manipulation:
 $$\begin{eqnarray}\displaystyle \frac{\text{d}^{2}{\it\sigma}}{\text{d}{\it\theta}^{2}} & = & \displaystyle {\it\sigma}+\frac{2}{{\it\sigma}}\left(\frac{\text{d}{\it\sigma}}{\text{d}{\it\theta}}\right)^{2}-\frac{2{\it\Omega}}{u_{s}{\it\sigma}}\left({\it\sigma}^{2}+\left(\frac{\text{d}{\it\sigma}}{\text{d}{\it\theta}}\right)^{2}\right)^{3/2}\nonumber\\ \displaystyle & & \displaystyle +\,\frac{{\it\Omega}^{2}}{u_{s}^{2}}\left({\it\sigma}^{2}+\left(\frac{\text{d}{\it\sigma}}{\text{d}{\it\theta}}\right)^{2}\right)\left[{\it\sigma}-\frac{{\it\sigma}_{0}}{{\it\sigma}}\left(\frac{\text{d}{\it\sigma}}{\text{d}{\it\theta}}\cos ({\it\theta}-{\it\beta})-{\it\sigma}\sin ({\it\theta}-{\it\beta})\right)\right],\qquad\end{eqnarray}$$
where
 ${\it\beta}$
is the angle between the
 $y$
-axis and the vector
 ${\bf\sigma}_{0}$
. This is a second-order, nonlinear, ordinary differential equation (ODE) that can be solved to yield
 ${\it\sigma}={\it\sigma}({\it\theta})$
. The only remaining unknown in (2.6) is the velocity along the streamline, which can be solved simultaneously using the
 $\hat{\boldsymbol{s}}$
-momentum equation:
 $$\begin{eqnarray}\frac{\text{D}u_{s}}{\text{D}t}=u_{s}\frac{\partial u_{s}}{\partial s}=-\frac{1}{{\it\rho}}\frac{\partial p}{\partial s}+\frac{{\it\mu}}{{\it\rho}}({\rm\nabla}^{2}\boldsymbol{u})\boldsymbol{\cdot }\hat{\boldsymbol{s}}+{\it\Omega}^{2}\boldsymbol{r}\boldsymbol{\cdot }\hat{\boldsymbol{s}}.\end{eqnarray}$$
At sufficiently low Reynolds numbers, viscous effects can inhibit span-wise flow in the LEV core (Birch, Dickson & Dickinson Reference Birch, Dickson and Dickinson2004). However, at Reynolds number of the order
 $O(10^{3})$
or greater, significant span-wise flow is observed in the core (Birch et al.
Reference Birch, Dickson and Dickinson2004; Harbig et al.
Reference Harbig, Sheridan and Thompson2013; Wojcik & Buchholz Reference Wojcik and Buchholz2014), and thus the viscous term in (2.7) is assumed to be negligible. The axial pressure gradients, however, cannot be neglected. In fact, Garmann & Visbal (Reference Garmann and Visbal2014) showed the span-wise pressure gradients to be an order of magnitude greater than centrifugal force in the flow over a rotating inclined plate. Maxworthy (Reference Maxworthy2007) developed a simplified model of a conical LEV, and showed that, in such a flow, the span-wise pressure gradient would scale in the same manner as centrifugal force. Thus, the following proportionality is implemented:
 $$\begin{eqnarray}-\frac{1}{{\it\rho}}\frac{\partial p}{\partial s}\propto {\it\Omega}^{2}\boldsymbol{r}\boldsymbol{\cdot }\hat{\boldsymbol{s}}.\end{eqnarray}$$
Introducing a constant of proportionality,
 $k$
, equation (2.7) becomes
 $$\begin{eqnarray}\frac{\partial u_{s}}{\partial s}=\frac{\text{d}u_{s}}{\text{d}s}=(k+1)\frac{{\it\Omega}^{2}}{u_{s}}\boldsymbol{r}\boldsymbol{\cdot }\hat{\boldsymbol{s}}.\end{eqnarray}$$
 $k$
is a dimensionless variable that describes the ratio of the axial pressure gradient to the centrifugal acceleration in the LEV core:
 $$\begin{eqnarray}k=-\frac{\text{axial pressure gradient}}{\text{centrifugal acceleration}}.\end{eqnarray}$$
When
 $k=0$
, centrifugal force drives the flow and pressure gradients are considered negligible. When
 $k\gg 1$
, the pressure gradient is dominant.
 $k$
will hereafter be referred to as the axial pressure gradient coefficient.
Expressing (2.9) in terms of the polar coordinate
 ${\it\theta}$
, the following expression is obtained:
 $$\begin{eqnarray}\frac{\text{d}u_{s}}{\text{d}{\it\theta}}=\frac{(k+1){\it\Omega}^{2}}{u_{s}}\left[{\it\sigma}\frac{\text{d}{\it\sigma}}{\text{d}{\it\theta}}+{\it\sigma}_{0}\left(\frac{\text{d}{\it\sigma}}{\text{d}{\it\theta}}\sin ({\it\theta}-{\it\beta})+{\it\sigma}\cos ({\it\theta}-{\it\beta})\right)\right].\end{eqnarray}$$
Given suitable boundary conditions, equations (2.6) and (2.11) can be solved to yield a unique solution for the trajectory of the axial streamline through an LEV core, and the velocity along that same streamline.
3 Boundary conditions and solution method
Equations (2.6) and (2.11) are coupled ODEs that can be solved simultaneously to yield the trajectory of a steady, axial streamline through a stable LEV core. To obtain a unique solution to the system of ODEs, three boundary conditions are required: (i) the initial location of the LEV,
 $\boldsymbol{r}_{0}$
, i.e. the most inboard location where a stable LEV core can be said to exist, (ii) the initial velocity along the streamline,
 $u_{s}({\it\theta}_{0})$
, and (iii) the initial trajectory of the LEV core,
 ${\it\sigma}^{\prime }({\it\theta}_{0})$
, which is taken to be parallel to the leading edge. A solution to the system of ODEs is obtained numerically using the built-in MATLAB® function ode45, which is an adaptive step-length Runge–Kutta solver.
The results of Garmann & Visbal (Reference Garmann and Visbal2014) and Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) are compared to two solutions of the model, denoted as solution 1 and solution 2, respectively. Boundary conditions (i) and (ii) for each solution are extracted directly from the corresponding study. In the case of Phillips et al. (Reference Phillips, Knowles and Bomphrey2015), this was made possible by the generous provision of raw data by the authors of that study. Boundary condition (iii) is obtained in both cases by assuming the axial streamline through the LEV core to be parallel to the leading edge at the starting location. The model parameters and boundary conditions for both solutions are summarized in table 1.
Note that the axis of rotation is aligned with the plate differently in these two studies; in the work of Garmann & Visbal (Reference Garmann and Visbal2014), it is aligned with the mid-chord, whereas it is aligned with the leading edge of the plate in the work of Phillips et al. (Reference Phillips, Knowles and Bomphrey2015). In both solutions, the origin of coordinate system
 $xyz$
lies on the axis of rotation, with
 $z$
parallel to the rotation vector.
Boundary conditions and other model parameters. Solution 1 was obtained for comparison to the results of Garmann & Visbal (Reference Garmann and Visbal2014), and solution 2 was obtained for comparison to the work of Phillips et al. (Reference Phillips, Knowles and Bomphrey2015). Boundary conditions (i) and (ii) are obtained from the studies against which each solution will be compared. The LEV is assumed to start parallel to the leading edge in both cases to yield boundary condition (iii).
 $\boldsymbol{r}_{0}$
and
 ${\bf\sigma}_{0}$
are expressed in
 $x$
- and
 $y$
-coordinates as
 $[x,y]$
.

4 Results and comparison to previous work
4.1 Comparison to the work of Garmann & Visbal (Reference Garmann and Visbal2014)
Garmann & Visbal (Reference Garmann and Visbal2014) conducted time-resolved numerical simulations of rotating, rectangular plates at an angle of incidence of
 $60^{\circ }$
relative to the swept plane. Since the presented model does not consider edge effects, such as the presence of the wing tip, the solution of the model is compared to the flow field around the plate of aspect ratio 4 in the work of Garmann & Visbal (Reference Garmann and Visbal2014), which is the largest aspect ratio they studied.
The estimated LEV trajectory in the work of Garmann & Visbal (Reference Garmann and Visbal2014) is taken as the locus of points within the primary LEV structure, as viewed on span-normal planes, where the span-wise vorticity is a maximum. These estimates are taken at an azimuthal angle of
 $67.5^{\circ }$
from the start of rotation. Beyond this azimuthal angle, evidence of vortex breakdown is apparent and complex substructures are superimposed onto the overall LEV structure, as viewed with isosurfaces of total pressure; nonetheless, by qualitative observation, the overall LEV core trajectory does not appear to change greatly (Garmann & Visbal Reference Garmann and Visbal2014). LEV trajectory data, as extracted from their published results in this way, are only available at locations up to the midspan.
Garmann & Visbal (Reference Garmann and Visbal2014) noted that span-wise pressure gradients in the LEV core are an order of magnitude greater in strength than centrifugal acceleration. As such, an axial pressure gradient coefficient of
 $k=10$
is used in the model.
Comparison of the LEV trajectory predicted by the presented model and the LEV core locations at various span-wise locations in the numerical simulation of Garmann & Visbal (Reference Garmann and Visbal2014): (a) isometric view, (b) projection onto the
 $x^{\prime }y$
-plane, i.e. the plane of the plate, (c) projection onto the
 $xz$
-plane. (d) The predicted velocity along the axial streamline versus span-wise position. An interactive three-dimensional plot of the LEV trajectory is provided in .fig format as supplementary material available at http://dx.doi.org/10.1017/jfm.2016.395.

Using the boundary conditions presented in table 1, solution 1 to the coupled system of ODEs predicts the observed LEV trajectory in the results of Garmann & Visbal (Reference Garmann and Visbal2014) quite well. Projections of the model solution and the numerical results onto the plate are very well aligned, as depicted in figure 3(b). However, as one moves outboard from the CoR, the observed LEV core locations tend to deviate from a
 $z$
-normal plane in a downwards direction, as shown in figure 3(c).
Inboard of the midspan, the predicted range of axial velocities in the LEV core, as plotted in figure 3(d), is in agreement with previous work, e.g. Birch et al. (Reference Birch, Dickson and Dickinson2004), Harbig et al. (Reference Harbig, Sheridan and Thompson2013), Wojcik & Buchholz (Reference Wojcik and Buchholz2014). Although the tip velocity has no effect on the solution of the system of ODEs, the velocity along the streamline is normalized as
 $u_{s}^{\ast \ast }=u_{s}/u_{tip}$
for consistency with previous literature, where
 $u_{tip}=4.5{\it\Omega}c$
in this case.
4.2 Comparison to the work of Phillips et al. (Reference Phillips, Knowles and Bomphrey2015)
Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) studied rectangular plates undergoing a simplified manoeuvre representative of the flapping motion of an insect wing. The plate was rotated about a vertical axis one chord length from the root of the plate, undergoing a rapid pitch motion from
 $90^{\circ }$
to
 $45^{\circ }$
angle of attack at the start of the manoeuvre. The angle of attack was then held constant for a period of time before the pitch and rotation were reversed to complete a symmetrical return stroke. For comparison to the steady-state model presented herein, their results for a plate of aspect ratio 4.5 at the time step closest to the end of the constant-pitch portion of the manoeuvre were considered. This time step corresponds to a dimensionless time of 0.4 (normalized by flapping period), and a traversed azimuthal angle of
 $61.5^{\circ }$
. The instantaneous LEV trajectory at this time is expected to approximate the steady-state trajectory, in accordance with the observations of Garmann & Visbal (Reference Garmann and Visbal2014) and Carr, DeVoria & Ringuette (Reference Carr, Devoria and Ringuette2015) for a plate of aspect ratio 4. As with the comparison to the work of Garmann & Visbal (Reference Garmann and Visbal2014), an axial pressure gradient coefficient of
 $k=10$
was used in the solution to the model.
Using stereo-PIV, Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) quantified the velocity field over the suction side of the plate on span-normal planes separated by 1 mm, or
 $0.033c$
. At each instant, they identified saddle points and foci on each span-normal plane, and the axis of the LEV was identified as the curve connecting the primary focus on each plane. Given the close spacing of the investigated planes, the LEV trajectory was identified with high spatial resolution. The model-predicted trajectory is compared to their experimental results over the most inboard
 $5/8$
ths of the span, outboard of which the vortex lifts dramatically from the plate surface due to interaction with the tip vortex. This arching of the LEV in the vicinity of the tip is also observed in the results of Garmann & Visbal (Reference Garmann and Visbal2014).
Comparison of the model-predicted LEV trajectory and the trajectory of the LEV axis and nearby streamlines in the experimental results of Phillips et al. (Reference Phillips, Knowles and Bomphrey2015): (a) isometric view, (b) projection onto the
 $x^{\prime }y$
-plane, i.e. the plane of the plate, (c) projection onto the
 $xz$
-plane. (d) Comparison of the predicted velocity along the axial streamline and the measured velocity along streamlines in the vicinity of the LEV core in Phillips et al. (Reference Phillips, Knowles and Bomphrey2015).

The LEV trajectory of solution 2 is in good agreement with the results of Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) for an aspect ratio of 4.5, as demonstrated in figure 4. Similar to figure 3, the projection of the results onto the plane of the plate shows excellent agreement (figure 4 b), whereas the greatest deviation between the experimentally identified LEV axis and the model is in the plate-normal direction (figure 4 c).
Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) also identified 69 individual streamlines in the vicinity of the vortex core at
 $t^{\ast }=0.4$
, which have also been plotted in figure 4. The velocity magnitude along these streamlines, as normalized by tip velocity, is plotted in figure 4(d). The axial streamline velocity predicted by the model matches these data well in the region inboard of the midspan, where the streamlines are closely clustered around the vortex core. Near the midspan, the streamlines begin to disperse from one another, while the velocity along the streamlines is decelerated; these observations are suggestive of vortex breakdown, which invalidates the model in this region.
A longer plate of aspect ratio 7.5 was also studied by Phillips et al. (Reference Phillips, Knowles and Bomphrey2015), and the LEV over this plate would be less influenced by the tip vortex over much of the span. However, the LEV trajectory over this plate does not appear to have reached steady state before the onset of the return-stroke manoeuvre, making it a poor candidate for comparison to the presented low-order model. This was concluded by noting that the LEV persists for much more than four chord lengths from the CoR for the plate of aspect ratio 7.5, in contradiction to the steady-state observations of Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015) for aspect ratios of 6.5, 8 and 10.
5 Discussion
5.1 Sources of error and sensitivity analysis
Deviations between the model and the results of Garmann & Visbal (Reference Garmann and Visbal2014) and Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) may have arisen from a combination of the following sources: (i) the LEV has not yet reached a steady-state trajectory at the chosen time step, (ii) uncertainty in the extracted boundary conditions and chosen
 $k$
-value for the model, (iii) the locus of points of local vorticity maxima on span-normal planes are not connected by a single streamline in the work of Garmann & Visbal (Reference Garmann and Visbal2014), and (iv) the LEV trajectory is influenced by the presence of the tip vortex.
Sensitivity of the predicted LEV trajectory to (a) the axial pressure gradient coefficient,
 $k$
, (b) to the initial trajectory of the LEV, i.e. to the initial angle between the axial streamline and the leading edge,
 ${\it\xi}_{0}$
, and (c) to the initial axial velocity,
 $u_{s}({\it\theta}_{0})$
. In all three plots, solid lines without markers represent the parameter value used in solution 1 for the comparison to the work of Garmann & Visbal (Reference Garmann and Visbal2014) in the results section above.

It can be observed qualitatively in the results of Garmann & Visbal (Reference Garmann and Visbal2014) that the LEV trajectory, as viewed using isosurfaces of total pressure, does not change significantly at times beyond the time-step analysed herein. As such, source of error (i) is thought to be small for both solutions. Source of error (ii) cannot be quantified, but the predicted LEV trajectory is relatively insensitive to the boundary conditions, as well as to the chosen axial pressured gradient coefficient
 $k$
, within reasonable limits (see figure 5). The magnitude of these uncertainties is not believed to be sufficiently great to negate the conclusions to be drawn.
In extracting the LEV trajectory from the numerical results of Garmann & Visbal (Reference Garmann and Visbal2014), it was assumed that the axial streamline would be closely aligned with the local maximum of vorticity on each span-normal plane. As one moves outboard from the CoR, the cross-section of the LEV grows, possibly leading to increased misalignment between the axial streamline and local vorticity maxima. However, so long as the axial streamline remains within the vortical LEV structure, the magnitude of source of error (iii) should be of similar magnitude to the uncertainties noted in (ii). Since the LEV trajectory from the results of Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) was identified directly from velocity data by the authors of that work, solution 2 is not affected by this source of error.
Lastly, the presence of the tip vortex induces a downwash to drive the LEV towards the plate. Indeed, the greatest deviation between the observed LEV trajectories in previous studies and the model-predicted trajectories are in the plate-normal direction, suggesting that source of error (iv) is likely the dominant source of error. The downwash argument is a kinematic one, and it is not clear how the presence of a tip vortex can be accounted for in a dynamic model such as the one presented herein. Nonetheless, the tendency of the tip vortex to keep the LEV closer to the plate will have an effect on the force generated, and future work to incorporate tip downwash effects into the LEV trajectory model would be useful.
5.2 Indirect comparison to the work of Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015)
In the recent work of Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015), the span-wise extent of a stable LEV, and a concomitant thin wake, was limited to three to four chord lengths from the CoR for plates of aspect ratios between four and ten. Limacher & Rival (Reference Limacher and Rival2015) suggested that, as one moves outboard from the CoR, the transition from a thin to a thick wake occurs where the stagnation point behind a bound LEV reaches the trailing edge. Garmann & Visbal (Reference Garmann and Visbal2014) similarly suggested that the length of the chord poses a limit on LEV growth, and thus on stable LEV attachment. In the context of the present work, as the LEV is tilted away from the leading edge, the aft stagnation point would necessarily move towards the trailing edge, as depicted in figure 1.
Let it be assumed that the aft stagnation point reaches the trailing edge at the span-wise location,
 $y_{t}/c$
, where the projection of the predicted axial streamline onto the plate reaches the mid-chord. This metric serves as a proxy for the span-wise extent of a stable LEV, allowing an indirect comparison to the results of Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015). The model is solved for a range of axial pressure gradient coefficients and initial axial velocities through the LEV core. Figure 6 shows how
 $y_{t}/c$
varies with
 $k$
and
 $u_{s0}^{\ast }$
, where
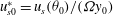 $u_{s0}^{\ast }=u_{s}({\it\theta}_{0})/({\it\Omega}y_{0})$
. The solutions in figure 6 correspond to the same geometry as investigated in the study of Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015): a root-to-CoR distance of
 $d/c=0.63$
, an angle of attack of
 ${\it\alpha}=45^{\circ }$
, and an alignment of the rotational axis to the quarter-chord location. The LEV starting location is taken to be
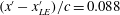 $(x^{\prime }-x_{LE}^{\prime })/c=0.088$
,
 $(y-d)/c=0.25$
, and
 $z^{\prime }/c=0.034$
, where
 $z^{\prime }$
represents the plate-normal direction. The LEV core is once again assumed to be parallel to the leading edge at the starting location.
The predicted thin-to-thick wake transition location,
 $y_{t}/c$
, for the geometry studied by Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015) as a function of axial pressure gradient coefficient,
 $k$
, and normalized axial velocity through the LEV core at the starting location,
 $u_{s0}^{\ast }$
. By comparison, for high aspect ratios, Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015) reported that a stable LEV, and concomitant thin wake, persist for four chord lengths from the CoR. Note that values of
 $k=10$
and
 $u_{s0}^{\ast }=5$
were used in the comparison to the work of Garmann & Visbal (Reference Garmann and Visbal2014).

For the range of parameters tested, the predicted values of
 $y_{t}/c$
are slightly below the reported span-wise extent of the LEV in Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015) for high aspect ratios (four chord lengths from the CoR). However, the predictions are well within the same order of magnitude, which is impressive given the simplicity of the proxy metric
 $y_{t}/c$
. The results in figure 6, in conjunction with the agreement seen in the more rigorous comparisons to the work of Garmann & Visbal (Reference Garmann and Visbal2014) and Phillips et al. (Reference Phillips, Knowles and Bomphrey2015), lend further credibility to the hypothesis that the centrifugal and Coriolis forces are significant in determining the steady-state trajectory of an LEV.
5.3 The role of Coriolis force in stable leading-edge vortices
The current work and the work of Garmann & Visbal (Reference Garmann and Visbal2014), Kruyt et al. (Reference Kruyt, van Heijst, Altshuler and Lentink2015), Limacher & Rival (Reference Limacher and Rival2015) and Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) present a consistent interpretation of the mechanisms that limit the span-wise extent of a stable LEV in a continuously rotating system. In this interpretation, a stable LEV is tilted away from the leading edge under the influence of centrifugal and Coriolis accelerations, which drives the stagnation point behind the LEV towards the trailing edge, to cause a transition to a thick, bluff-body type wake within several chord lengths from the root of rotation. This wake transition is associated with the maximum span-wise extent of a stable LEV. The exact correlation between the wake transition location and a decrease in local force coefficients is not clear, and warrants further study.
Interestingly, in addition to limiting stable LEVs to locations near the CoR, Coriolis acceleration may be responsible for the associated force-enhancement. By running several simulations with the centrifugal and Coriolis terms included or artificially removed, Jardin & David (Reference Jardin and David2015) showed that the exclusion of Coriolis acceleration caused the greatest decrease in the force history. They also showed that the stream-wise Coriolis acceleration is predominantly concentrated in the LEV core, which supports the notion that Coriolis force is a key driver of the steady-state LEV trajectory.
Previous studies have discussed Coriolis force as being either a stabilizing or a destabilizing force. Lentink & Dickinson (Reference Lentink and Dickinson2009) suggested that the Coriolis force aids in driving span-wise convection of vorticity to limit the growth of an LEV and permit stable attachment. Garmann & Visbal (Reference Garmann and Visbal2014) cast some doubt on this hypothesis, having shown that the span-wise pressure gradients are an order of magnitude greater than the span-wise projection of Coriolis force. They also noted that Coriolis force has a component normal to the chord, driving fluid away from the plate; in this sense, one might call Coriolis force a destabilizing force. However, acceleration of fluid in the LEV core away from the plate is not necessarily associated with convection of the core, but could merely accompany curvature of the LEV in steady state. In the alternative view of the role of Coriolis force presented here, stabilizing or destabilizing are incomplete descriptions.
6 Conclusion
The role of Coriolis force in stable LEVs over rotating plates has been a topic of discussion in the literature. Herein, it is postulated that Coriolis force plays a significant role in determining the span-wise extent of a stable LEV by tilting it away from the leading edge and into the wake. To test this hypothesis, a simplified model was developed by considering the accelerations acting on a mean streamline aligned with the core of the LEV. The resulting system of coupled ODEs can be solved to predict the trajectory of such a streamline and, by association, the trajectory of the overall LEV structure. Using boundary conditions from Garmann & Visbal (Reference Garmann and Visbal2014) and Phillips et al. (Reference Phillips, Knowles and Bomphrey2015), the model predicts the observed LEV trajectories in each of those works quite well. By assuming Coriolis force to dominate the LEV-tilting process, the model predicts that the span-wise extent of a stable LEV will be limited to several chord lengths from the root of rotation, which is in agreement with previous observations (Lentink & Dickinson Reference Lentink and Dickinson2009; Kruyt et al. Reference Kruyt, van Heijst, Altshuler and Lentink2015). The only significant differences between the predicted LEV trajectories and previous observations are in the plate-normal direction, and it is speculated that these deviations are due to the downwash generated by the tip vortex.
Acknowledgements
The authors would like to thank Dr N. Phillips, Professor K. Knowles and Dr R. J. Bomphrey for generously sharing their raw data from their 2015 publication in Bioinspir. Biomim., cited throughout this paper as Phillips et al. (Reference Phillips, Knowles and Bomphrey2015) with the full citation in the references below. Access to their data allowed for the detailed comparison to our model portrayed in figure 4, which has certainly added to the strength of this work.
Supplementary material
Supplementary material is available at http://dx.doi.org/10.1017/jfm.2016.395.



