1. Introduction
With the burgeoning development of intelligent factories, high-performance trajectories are very beneficial to improving the accuracy of trajectory tracking control and promoting diverse applications of automatic mobile and multi-degree of freedom (DOF) robots in the dynamic working environment. In point-to-point trajectory planning, typical indicators for evaluating trajectory performance mainly include collision avoidance [Reference Li, Ran and Xie1], singularity avoidance [Reference Jin, Rocco and Geng2], vibration suppression [Reference Zheng, Hu and Wu3, Reference Biagiotti, Melchiorri and Moriello4], and time-energy-jerk optimization [Reference Peng, Chen, Tang, Miao and Li5]. In addition to typical offline trajectory planning, online trajectory planning is considered an effective way to check the efficient synchronous motion of robots [Reference Liang, Yao, Wu, Wang and Wang6, Reference Cappo, Desai, Collins and Michael7, Reference Zhao and Sidobre8].
As the basis core technology of robot systems, trajectory planning takes a given geometric path and then endows it with the time information. The geometric path is generated by discrete path points and interpolation methods. Typical interpolation methods mainly contain the linear, circular, polynomial, and spline-curve interpolation methods. For robots with continuous velocity and acceleration in the complex working environment, polynomial and spline-curve interpolation methods are more suitable for fitting discrete path points than linear and circular interpolation methods. Chu et al. employed the polynomial interpolation method to generate continuous and smooth trajectories for the end effector of the manipulator [Reference Chu, Hu and Zhang9]. Lan et al. used seven-order B-spline functions to construct joint trajectory sequences to ensure the continuity of the trajectory curve [Reference Lan, Xie, Liu and Cao10]. Wu et al. adopted non-uniform rational B-spline curves to fit discrete control points of the trajectory for serial robotic manipulators [Reference Wu, Zhao and Zhang11, Reference Sathiya and Chinnadurai12].
To meet various demands of fast-paced flexible production, multi-robot trajectory planning quickly attracts the attention of related researchers. Typical methods in the field mainly include centralized and decentralized trajectory planning. Gravell and Summers demonstrated tractable centralized methods for generating multi-robot trajectories with collision-free goal assignment. Numerical experiments showed that the proposed method significantly reduced the total time [Reference Gravell and Summers13]. Based on virtual motion camouflage and particle swarm optimization, Kwak et al. investigated a decentralized method of trajectory optimization to solve non-linear problems constrained by the multi-robot terminal time and angle. Simulation and experimental results showed that the generated path was effective [Reference Kwak, Choi, Cho, Kim and Lee14, Reference Kandhasamy, Kuppusamy and Krishnan15]. Combined with the artificial potential field method, the neighbourhood system, and the notion of priority between robots, Matoui et al. used distributed architecture to plan trajectories of a multi-robot system. The simulation showed that the proposed method was available [Reference Matoui, Boussaid and Abdelkrim16].
The multi-robot trajectory performance is affected by multiple single-robot trajectory performances, especially in the periodic production line. To determine productivity-optimal or energy-optimal coordinated trajectories for cyclic multi-robot systems, Glorieux et al. used a non-linear programming optimization model and multi-robot coordination based on velocity tuning and time delays. Results showed that 50% smoother trajectories and 14% reduction in energy consumption for the same productivity were achieved [Reference Glorieux, Riazi and Lennartson17]. Additionally, to minimize the deformation during handling compliant parts for multi-robot systems, Glorieux et al. proposed an optimization method using a precomputed Response Surface Model. Results showed that the optimized trajectory was validated, and the deformation of the handling part was significantly reduced [Reference Glorieux, Franciosa and Ceglarek18].
Trajectory properties such as velocity, acceleration, and jerk affect the trajectory tracking ability of robotic control systems. They may seriously affect the control difficulty and control accuracy [Reference Wang, Zhu, Qi, Zheng and Li19]. Trajectories with high performance are beneficial to relieving the pressure of robotic control systems. Based on the existing trajectories, many scholars focus on the research of controllers and control strategies to accurately track predetermined position sequences in time. To ensure high-precision trajectory tracking of the control system, Li proposed a method of robot vision localization based on the iterative Kalman particle filter. Experimental and simulation results showed that the proposed algorithm was feasible and effective [Reference Li20]. Considering collisions, deadlocks, and time, Gregoire et al. designed a control strategy to handle the exogenous disturbance. Experiments confirmed that the proposed method ensured the generation of deadlock-free trajectory with smaller time [Reference Gregoire, Cap and Frazzoli21]. To investigate the fixed-time trajectory tracking control for a group of non-holonomic mobile robots, Ou et al. developed distributed fixed-time tracking controllers adding a power integrator technique. Simulation results illustrated and verified the effectiveness of the proposed scheme [Reference Ou, Sun, Zhang and Li22].
The above research has revealed multi-robot trajectory planning considering multiple optimal indicators. However, there is little research on local variable-period trajectory optimization of multi-DOF robots. Most research focuses on fixed-period or global variable-period trajectory optimization. If the robot or manipulator runs under the local variable-period operation, the whole procedures of the trajectory planning will be re-executed. It consumes much time and deteriorates the original trajectory performance at the unchanged fixed-time interval. To evaluate the robotic trajectory performance such as working productivity, energy consumption, and vibration suppression, the feeding velocity of the periodical running robot is increased from small to large. For the multi-robot coordination in the stamping line, initial periods of robots are generally different. The feeding velocity at certain moments should be independently adjusted to ensure the continuous and periodic running of robots. Some robots even stop and wait for other robots to arrive at the pre-set position before starting a new cycle of periodic motion, which may increase energy consumption and shorten robot life. Under this circumstance, based on the quintic B-spline curve and normal distribution, a smooth interpolation method of variable-time interval is proposed to improve the trajectory performance for multi-manipulator coordination in the high-speed automobile-panel stamping line.
Compared with the existing methods, the proposed method can locally optimize the fluctuation period and simultaneously generate high-performance trajectories in Cartesian and joint space. It can save much time, especially in harsh working conditions. Additionally, the proposed method is not equivalent to feedrate planning. The main difference between feedrate planning and the proposed method is that path points in the region of local variable-time interval are not constant. To generate the collision-free and energy-jerk-minimal trajectory, positions of some path points may be changed.
The rest of the paper is organized as follows. Section 2 conducts the generation of the local variable period for multiple redundant manipulators in the high-speed automobile-panel stamping line. Section 3 introduces detailed steps of the proposed method. Section 4 completes the simulation and experiment of the proposed method. Sections 5 and 6 are discussion and conclusions, respectively.
2. Generation of the local variable period in the stamping line
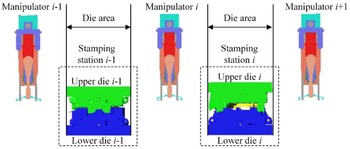
As the typical application scenario of industrial robots, the high-speed automobile-panel stamping line alternately cooperates with multiple feeding mechanisms and stamping stations for completing material transmission and stamping forming [Reference Yu, Wang, Zhang, Zhang and Zhang23]. Specifically, when the upper and lower dies of the stamping station i-1 are separated to a certain height, the manipulator i starts to move from the initial pose in Fig. 1 to a certain height above the lower die i-1 to pick up the stamping part. Then, the manipulator i transfers the stamping part to place the stamping part in the lower die i. Finally, the manipulator i moves to the initial pose in Fig. 1 to start the next cycle of work. Notably, when the manipulator leaves the die area of the stamping station i, stamping forming of the stamping part will be executed.
Initial poses of multiple machines in the stamping line.

The trajectory performance of the stamping line is affected by trajectories of feeding mechanisms and stroke curves of presses in the stamping station. The feeding mechanism in Fig. 1 is the redundant manipulator. The stamping station includes the upper die, lower die, and press. The press is located inside the upper die. In the single-machine trajectory planning, motion periods of press and manipulator are generally different. The manipulator with periodic material transmission may collide with up to six neighbouring models. The manipulator i in Fig. 1 is taken as an example. It may simultaneously collide with manipulators i-1 and i + 1, upper dies i-1 and i, lower dies i-1 and i in one motion period. To ensure the continuous running of multiple machines in Fig. 1, the motion period of the manipulator should be adjusted to be the same as that of the press.
The manipulator i in Fig. 1 picks up stamping part from the lower die i-1 and places stamping part in the lower die i. The district of the stamping station in the horizontal direction is called the die area. Based on Eq. (1), the period P
M
of the manipulator before multi-machine coordination is discretized into
 $n_{M}$
time points.
 \begin{equation} t_{M}=\frac{P_{M}}{n_{M}-1} \end{equation}
where
 $t_{M}$
is the fixed-time interval of the manipulator before multi-machine coordination.
 $n_{M}$
is the number of discrete time points.
When the manipulator i in Fig. 1 enters and exits the die area of the stamping station i-1, corresponding labelled numbers of discrete time points are assumed to be m
1 and m
2, respectively. Similarly, when the manipulator i enters and exits the die area of the stamping station i, corresponding labelled numbers of discrete time points are assumed to be m
3 and m
4, respectively. If the manipulator runs for one period, the total number of discrete fixed time points in the die area will be assumed to
 $n_{M\_ in}$
. From the perspective of labelled numbers,
 $n_{M\_ in}$
can be obtained by Eq. (2).
 \begin{equation} n_{M\_ in}=m_{2}-m_{1}+m_{4}-m_{3} \end{equation}
Decentralized trajectory planning is widely used in the high-speed automobile-panel stamping line. Trajectory planning of the single redundant manipulator is firstly executed. Then, the period of the stamping line is generated. The period of the single redundant manipulator is not less than that of the stamping line. If multi-machine coordination is executed, the period of the single redundant manipulator will increase to the same as that of the stamping line. The period difference between the period of the stamping line and that of the manipulator is defined as
 $P_{d}$
. It can be determined by Eq. (3).
 \begin{equation} P_{d}=P_{S}-t_{M}n_{M\_ in} \end{equation}
where
 $P_{S}$
is the period of stamping line after multi-machine coordination.
Before the multi-machine coordination, the period of the manipulator is greater than that of press. To ensure high-speed and continuous running of the stamping production line, the time interval of the manipulator in the die area is equal to its initial fixed time interval. The time interval of the manipulator out of the die area should be greater than that in the die area.
3. Smooth interpolation method of variable-time interval
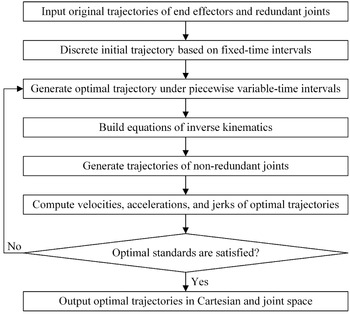
Improper distribution of time intervals out of die area may generate poor-performance trajectories in Cartesian and joint space. To maintain the original trajectory performance of the stamping line after the variable-period operation, detailed steps of the proposed method in Fig. 2 are introduced in this section.
Steps for the smooth interpolation method of variable-time interval.

Step 1: Input original trajectories of end effectors and redundant joints
Assume that the redundancy of the N-DOF manipulator is R. Joints of the manipulator are divided into redundant and non-redundant joints. Trajectories of end effectors and redundant joints are preferentially input.
Step 2: Discrete initial trajectory based on fixed-time intervals
Based on Eq. (1), the input trajectory is discretized. The recommended
 $n_{M}$
is approximately 4000. If
 $n_{M}$
is too small, one fixed-time interval will occupy much time to deteriorate the optimal trajectory performance, and invalid solutions of non-redundant joints will be generated. If
 $n_{M}$
is too large, the time consumption of trajectory optimization will be increased.
Step 3: Generate optimal trajectory under piecewise variable-time intervals
In the die area, time intervals of input trajectories remain constant. Combined with
 $P_{d}$
in Eq. (3), time intervals of input trajectories out of the die area should be adjusted. To ensure the smooth transition of the trajectory, the changing trend of variable-time increments is slow, fast, and slow. Under this circumstance, normal distribution in Eq. (4) is introduced. It highly matches the changing requirement of variable-time intervals and is easy to operate in MATLAB. However, there are many unknown parameters in Eq. (4), which increases the uncertainty of time allocation.
 \begin{equation} f\left(t\right)=\frac{1}{\sqrt{2\pi }\sigma }e^{-\frac{\left(t-\mu \right)^{2}}{2\sigma ^{2}}},-\infty \lt t\lt +\infty \end{equation}
Where
 $\mu$
is average,
 $\sigma$
is standard deviation, t is the random variable, and f(t) is the probability density function.
If
 $\mu$
and
 $\sigma$
are constant, Eq. (4) will be transformed into t∼N(
 $\mu, \sigma ^{2}$
). Combined with the normal distribution function named normpdf in MATLAB, the curve of the normal distribution can be plotted in Fig. 3.
Normal distribution.

As shown in Fig. 3, assume that t in Eq. (4) ranges from -t
i
to t
j
. Within this rang,
 $P_{d}$
in Eq. (3) is equal to the integral area of the curve with respect to the horizontal coordinate. To maintain the consistent number of trajectory points, the number of time points between -t
i
and t
j
should satisfy the Eq. (5).
 \begin{equation} n_{t}=n_{M}-n_{M\_ in} \end{equation}
where n t is the number of time points.
There are two variable-period districts for manipulator i in Fig. 1. One district is the manipulator transferring the stamping part from stamping stations i-1 to i out of the die area. The other district is the manipulator running from stamping stations i to i-1 out of the die area. In this section, the former district is taken as an example to illustrate the generation of optimal trajectory under piecewise variable-time intervals. For the manipulator transferring stamping part from stamping stations i-1 to i out of the die area, labelled numbers of discrete time points range from m
2 to m
3. Meanwhile, corresponding piecewise variable-time intervals
 $t'_{\!\!I}$
can be obtained by Eq. (6). Notably,
 $t'_{\!\!I}$
is the increment of variable-time interval relative to fixed-time interval.
 \begin{equation} t'_{\!\!I}=t'_{\!\!I-1}+t_{M}+P'_{\!\!d}\frac{T_{I}}{\sum _{I^{\prime}=1}^{m_{3}-m_{2}}T_{I^{\prime}}} \end{equation}
where I ranging from 1 to (m
3-m
2) is the sequence number of discrete time points.
 $t'_{\!\!0}$
is equal to the time increment whose labelled number of discrete time point is m
2. T
I
in Eq. (7) is the single-step increment ratio of
 $P'_{\!\!d}$
.
 $P'_{\!\!d}$
in Eq. (8) is the time difference between the time of the optimal trajectory and that of the initial trajectory when the manipulator transferring stamping part from stamping stations i-1 to i out of the die area.
 \begin{equation} T_{I}=\text{normpdf}\left(I\frac{\left(t_{i}+t_{j}\right)t_{M}n_{t}}{P_{d}\left(m_{3}-m_{2}\right)}-t_{i}, \mu,\sigma \right) \end{equation}
 \begin{equation} P'_{\!\!d}=\frac{m_{3}-m_{2}}{n_{M}-n_{M\_ in}}P_{d}-\left(m_{3}-m_{2}\right)t_{M} \end{equation}
To ensure the smooth and symmetrical transition of the variable-time interval, t
i
and t
j
are assumed to be identical. The generated
 $t'_{\!\!I}$
in Eq. (6) replacing the original fixed time point out of the die area becomes the new piecewise variable time point. But the trajectory value corresponding to the time point remains unchanged.
Step 4: Build equations of inverse kinematics
Based on the Denavit-Hartenberg or geometric method, equations of forward kinematics can be obtained. Equations of inverse kinematics from Cartesian space to joint space can be further built.
Step 5: Generate trajectories of non-redundant joints
In one motion period, time intervals of non-redundant joints correspond to that of end effectors and redundant joints under piecewise variable-time intervals. Combined with inverse kinematic equations in Step 4, the trajectory of the non-redundant joint can be further ensured.
Step 6: Compute velocities, accelerations, and jerks of optimal trajectories
Assume that there is one knot vector U={u 0, u 1, …, u m } and n + 1 control points P 0, P 1, …, P n . The B-spline curve p(u) of degree k defined by knot vector and control points is shown in Eq. (9).
 \begin{equation} p\left(u\right)=\sum _{i=0}^{n}N_{i,k\left(u\right)}P_{i} \end{equation}
where, N i,k(u) is the B-spline basis function of degree k. Its mathematical expression is shown in Eq. (10). Notably, m=n+k + 1.
 \begin{equation} \left\{\begin{array}{l} N_{i,0\left(u\right)}=\left\{\begin{array}{l} 1,\;if\; u_{i}\leq u\leq u_{i+1}\\[5pt] 0,\;\textit{otherwise} \end{array}\right.\\[16pt] N_{i,k\left(u\right)}=\dfrac{u-u_{i}}{u_{i+k}-u_{i}}N_{i,k-1}\left(u\right)+\dfrac{u_{i+k+1}-u}{u_{i+k+1}-u_{i+1}}N_{i+1,k-1}\left(u\right) \end{array}\right. \end{equation}
A series of discrete trajectory points can be fitted by the quintic B-spline curve in Eq. (9). The programme of the proposed method is executed in MATLAB. Table I lists several typical B-spline postprocessing functions in MATLAB.
Typical B-spline postprocessing functions in MATLAB.

Combined with Eq. (9) and functions in Table I, displacements, velocities, accelerations, and jerks of optimal trajectories under piecewise variable-time intervals can be obtained.
Step 7: Output optimal trajectories in Cartesian and joint space
A sharp point in the motion curve may bring an abrupt change of force and acceleration. The transient vibration and overshoot of the manipulator may further occur. The lower the transient vibration and overshoot of the manipulator are, the higher performance the motion trajectory will be ref. [Reference Gao, Li, He and Li24]. Additionally, the average acceleration is related to the torque reflecting the energy consumption of motor [Reference Lan, Xie, Liu and Cao10]. From the perspective of the trajectory planning, to maintain the high performance of motion trajectory, following optimal standards should be satisfied.
-
I. There is no sharp point on the velocity curve during one motion period.
-
II. There is no collision among machines during continuous motion periods.
-
III. The multi-objective optimization function in Eq. (11) should be satisfied.
(11) \begin{equation} \begin{array}{l} \min f_{1}=\sum \sqrt{\frac{1}{P_{M}}\int _{0}^{P_{M}}a_{i}^{2}dt}\\[5pt] \min f_{2}=\sum \sqrt{\frac{1}{P_{M}}\int _{0}^{P_{M}}j_{i}^{2}dt}\\[5pt] \!s.t. \left| a_{i}\right| \leq a_{\max }\\[5pt] \quad\; \left| \,j_{i}\right| \leq j_{\max } \end{array} \end{equation}

where f 1 and f 2 are functions to measure the energy consumption and evaluate the smoothness of the trajectory, respectively [Reference Lan, Xie, Liu and Cao10]. a max and j max are maximum values of acceleration and jerk, respectively. P M is the period of the manipulator.
Before the local variable-period trajectory optimization, the initial fixed-period trajectories meet the application requirement. Compared with f 1 and f 2 of the initial fixed-period trajectory, if f 1 and f 2 of the local variable-period trajectory are not significantly increased, the optimal standard III will be satisfied. If above optimal standards are satisfied, optimal trajectories in Cartesian and joint space can be output. Otherwise, Steps 3 to 7 will be re-executed. The proposed method will not be terminated until the optimal trajectory satisfying the above standards is generated.
4. Case study
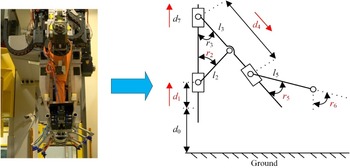
The redundant planar manipulator with 5 DOFs in Fig. 4 is taken as the case to illustrate the proposed method. The redundancy of the manipulator is 2. In the previous work [Reference Yu, Wang, Zhang and Zhang25], trajectories in Cartesian and joint space can be obtained by the method based on the joint classification and particle swarm optimization algorithm. Joints D
4 and R
6 are redundant joints. They are beneficial to avoid the generation of singularities during the trajectory planning of the single redundant planar manipulator. The period of the trajectory is 3.75 s. It is discretized into 4097 time points. Corresponding labelled numbers m
1, m
2, m
3, and m
4 are 531, 1846, 2306, and 3552. Based on Eq. (2),
 $n_{M\_ in}$
is 2561. The period
 $P_{S}$
of the stamping line is assumed to be 5.6881 s. Based on Eq. (3),
 $P_{d}$
is approximately 3.3434 s. Additionally, some definitions and values of parameters in Fig. 4 are listed in the previous published paper [Reference Yu, Wang, Zhang and Zhang25].
The redundant planar manipulator.

The trajectory in the vertical direction in Cartesian space is prioritized for variable-period operation. To ensure the high performance of the trajectory, t
i
and t
j
in Fig. 3 are both 8. Two stamping stations i-1 and i in Fig. 1 divide the motion trajectory of manipulator i into four sections. Two sections are out of the die area. Based on m
2 and m
3, the number of time intervals for manipulator i running from stamping stations i-1 to i out of the die area is 460. Based on Eq. (8), the corresponding
 $P'_{\!\!d}$
is 0.5801 s.
 $\mu$
and
 $\sigma$
in Eq. (4) are 0 and 3.2, respectively. Similarly, based on
 $n_{M}$
, m
1 and m
4, the number of time intervals and corresponding
 $P'_{\!\!d}$
for manipulator i running from the stamping stations i to i-1 out of the die area are 1076 and 1.3570 s, respectively.
 $\mu$
and
 $\sigma$
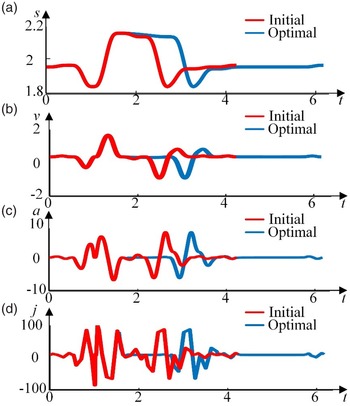
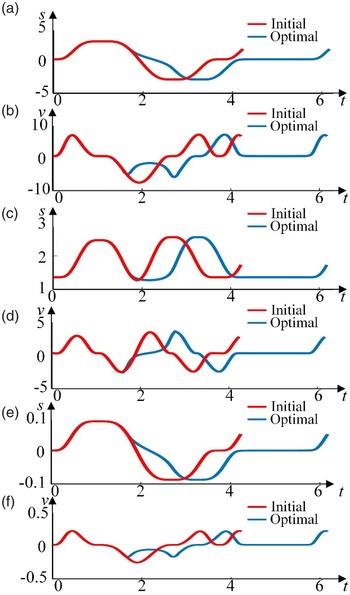
in Eq. (4) are 0 and 1, respectively. Combined with Eq. (7) and functions in Table I, the new increment of time intervals out of the die area can be obtained. Combined with Eq. (6), the original trajectory points corresponding to fixed-interval time points are transformed into that corresponding to variable-interval time points. The optimal trajectory of end effector in the vertical direction in Cartesian space can be shown in Fig. 5. Notably, units of displacement s, velocity v, acceleration a, jerk j, and time t are m, m/s, m/s2, m/s3, and s, respectively. The red and blue curves in Fig. 5 represent curves of initial and optimal trajectories, respectively.
The end-effector optimal trajectory in the vertical direction. (a) Displacement-time curve, (b) Velocity-time curve, (c) Acceleration-time curve, (d) Jerk-time curve.

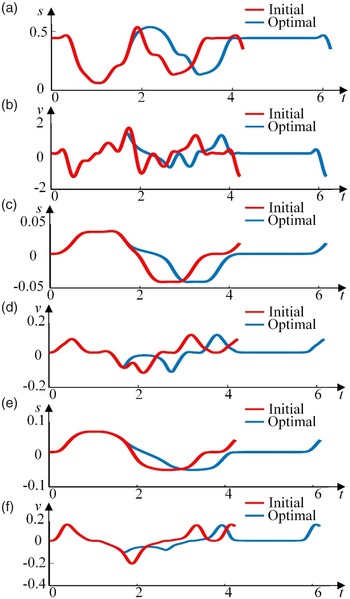
In Fig. 5, the manipulator starts at the initial position, runs in one period, and ends in the pose whose labelled number of time points is again m 1. The whole periods of curves represented by the red and blue curves are 4.2352 and 6.1733 s, respectively. Similarly, as shown in Fig. 6, trajectories of redundant joints and end effector in the horizontal direction under piecewise variable-time intervals can be generated. Notably, units of displacements and velocities for revolute joints are o and o/s, respectively. The red and blue curves in Fig. 6 represent curves of initial and optimal trajectories, respectively.
Variable-period trajectories of redundant joints and end effector in the horizontal direction. (a) Displacement-time curve of the end effector in the horizontal direction, (b) Velocity-time curve of the end effector in the horizontal direction, (c) Displacement-time curve of joint D 4, (d) Velocity-time curve of joint D 4, (e) Displacement-time curve of joint R 6, (f) Velocity-time curve of joint R 6.

Based on the geometric method, forward kinematic equations of the redundant planar manipulator in Fig. 4 can be shown in Eq. (12).
 \begin{equation} \left\{\begin{array}{l} x=d_{4}\sin r_{3}+l_{5}\sin \left(r_{3}+r_{5}\right)\\[5pt] y=d_{0}+d_{1}+l_{2}\cos r_{2}-\left(d_{4}-l_{3}\right)\cos r_{3}-l_{5}\cos \left(r_{3}+r_{5}\right)\\[5pt] r_{6}=r_{3}+r_{5}\\[5pt] l_{2}\sin r_{2}=l_{3}\sin r_{3} \end{array}\right. \end{equation}
The Eq. (12) is transformed into equations of inverse kinematics in Eq. (13).
 \begin{equation} \left\{\begin{array}{l} r_{3}=\arcsin \dfrac{x-l_{5}\sin r_{6}}{d_{4}}\\[9pt] r_{2}=\arcsin \dfrac{l_{3}\sin r_{3}}{l_{2}}\\[5pt] r_{5}=r_{6}-r_{3}\\[5pt] d_{1}=y-d_{0}-l_{2}\cos r_{2}+\left(d_{4}-l_{3}\right)\cos r_{3}+l_{5}\cos \left(r_{3}+r_{5}\right) \end{array}\right. \end{equation}
Under piecewise variable-time intervals, trajectory points of non-redundant active joints D 1, R 2, and R 5 can be obtained by Eq. (13). Combined with Eq. (9) and functions in Table I, their displacements, velocities, accelerations, and jerks can be further generated. Combined with Eq. (11) and standards in Section 3, the high-performance trajectories of non-redundant active joints are shown in Fig. 7. The red and blue curves in Fig. 7 represent curves of initial and optimal trajectories, respectively. f 1 and f 2 of trajectories are shown in Table II.
Variable-period trajectories of non-redundant active joints. (a) Displacement-time curve of joint D 1, (b) Velocity-time curve of joint D 1, (c) Displacement-time curve of joint R 2, (d) Velocity-time curve of joint R 2, (e) Displacement-time curve of joint R 5, (f) Velocity-time curve of joint R 5.

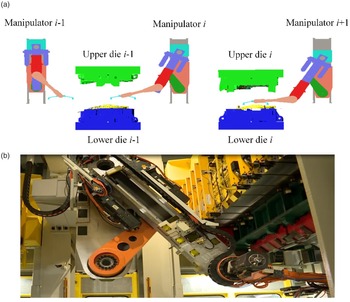
In Table II, X and Y represent end-effector trajectories in the horizontal and vertical directions, respectively. Units of f 1 and f 2 for R 2, R 5, and R 6 are o/s 2 and o/s 3, respectively. Similarly, units of f 1 and f 2 for other parameters are m/s2 and m/s3, respectively. To intuitively compare f 1 and f 2 in the initial and optimal trajectories, P M in Eq. (11) is adjusted to 4.2352 s. f 1 and f 2 in the initial and optimal trajectories are approximately identical. They are less than a max and j max, respectively. In addition, as shown in Fig. 8, trajectories of active joints are imported to the operation platforms of ADAMS and related actual manipulators, respectively. Simulation and experiment results also show that there is no collision between the manipulator and neighbouring machines. Curves of trajectories and velocities in ADAMS and experiment are consistent with those in MATLAB. Combined with standards in Section 3, Figs. 5–7, and Table II, the generated optimal variable-period trajectories for the redundant planar manipulator in Fig. 4 are available.
f 1 and f 2 corresponding to initial and optimal trajectory.

5. Discussion
This section discusses optimal results obtained by a smooth interpolation method of variable-time interval. The proposed method is based on the quintic B-spline curve and normal distribution. Productivity and stability are two crucial evaluation indicators for the feeding manipulator in the high-speed automobile-panel stamping line. The feeding manipulator should avoid collision with neighbouring dynamic and static machines. To ensure the continuous and periodic motion of the stamping line, the motion time of the feeding manipulator entering and exiting the die area should be adjusted based on stoke curves of neighbouring presses and trajectories of neighbouring manipulators. The original trajectory planning method based on fixed-time intervals may not be suitable for this application scenario.
The motion state of the manipulator at one moment (a) ADAMS (b) Experiment.

To improve the efficiency of trajectory optimization, this paper employs a smooth interpolation method of variable-time interval, which can divide the initial trajectory based on fixed-time intervals into fixed-time and variable-time interval districts. Combined with the application requirement, the proposed method can generate several variable-time interval districts with specific time increments. In this paper, the initial trajectory is divided into two variable-time interval districts. Meanwhile, to maintain the high performance of the initial trajectory, variable-time intervals are generated based on the normal distribution. For a specific variable-time interval district, the value of the fixed-time interval is constant. Combined with the curve trend of the normal distribution, the pre-set time increment is discretized into small time increments and allocated to fixed-time intervals in the variable-time interval district. Under this circumstance, values of variable-time intervals will increase slowly, quickly, and slowly. The changing trend of the variable-time intervals is beneficial to ensuring the smooth transition of the pre-set time increment. The combination of t
i
, t
j
,
 $\mu$
, and
 $\sigma$
in Eq. (7) affects the distribution of time increments and trajectory performances. Improper values of combination parameters can generate more sharp points in the displacement or velocity curves.
The existence of sharp points in the motion curve may deteriorate the trajectory performance. Sharp points easily appear in the transition region between fixed-time and variable-time interval districts. Affected by the value of the time increment, the performance of the generated optimal trajectory can be significantly reduced. Under this circumstance, some fixed-time points in this region can be ignored. As shown in Figs. 5–7, there are 400 fixed-time intervals that are temporarily ignored around the transition area. Specifically, labelled numbers of ignored time points are 1646 to 1846 and 2306 to 2506. Otherwise, the generated trajectory under piecewise variable-time intervals will appear more sharp points. Values of f 1 and f 2 will be significantly increased. After spline fitting based on the quintic B-spline curve, trajectory values corresponding to temporarily ignored time intervals can be re-obtained.
The proposed smooth interpolation method of variable-time interval is suitable for mobile and multi-DOF robots. The generation of local variable-period trajectory for end effector in Cartesian space and redundant joints in joint space is suitable for mobile robots. On this basis, combined with kinematic equations in Eqs. (12) and (13), trajectories of non-redundant joints for multi-DOF robots are quickly obtained. For multi-DOF robots, the trajectory performance of the end effector in Cartesian space and redundant joints in joint space directly determine the pros and cons of non-redundant joints in joint space. Therefore, it is important to generate high-performance trajectories of the end effector in Cartesian space and redundant joints in joint space under the smooth interpolation method of variable-time interval.
Compared with the other research on variable-period trajectory optimization of multi-DOF robots [Reference Yu, Wang, Zhang, Zhang and Zhang23, Reference Yu, Wang, Zhang and Zhang25], main contributions of the paper can be cleared as follows. Firstly, the proposed method applies to the multi-segment local variable-period operation of trajectory optimization and maintains the initial trajectory performance. Secondly, the proposed method can ensure the continuous and periodic running of all machines during the multi-machine coordination, which is beneficial to reducing energy consumption and extending machine life. Finally, the new trajectory generated by the smooth interpolation method of variable-time interval can be directly used for mobile and multi-DOF robots, which can effectively avoid the entire process of secondary trajectory planning and improve the efficiency of trajectory optimization. However, affected by parameters
 $P_{d}$
, and t
i
, t
j
,
 $\mu, \sigma$
in Eq. (7), the current efficiency of the proposed method cannot satisfy the application requirement of online trajectory optimization. Specifically, if
 $P_{d}$
in Eq. (3) is larger, the combined adjustment of parameters t
i
, t
j
,
 $\mu$
, and
 $\sigma$
in Eq. on (7) will be difficult. It affects the reasonable distribution of time increment in the variable-period trajectory optimization.
6. Conclusions
This paper investigates trajectory optimization of local variable period for mobile and multi-DOF robots in the high-speed automobile-panel stamping line. The combinatorial optimization of high productivity and low chatter is a critical issue. For this aim, based on the quintic B-spline curve and normal distribution, the smooth interpolation method of variable-time interval is proposed to directly generate and optimize the local variable-period trajectory. Compared with the traditional trajectory planning based on fixed-time intervals, the proposed method can adjust the time interval in time under emergency working conditions. It is very beneficial to properly improve the efficiency of trajectory optimization after multi-machine coordination in the stamping line.
There is no sharp point in the optimal displacement and velocity curves with local variable period. Additionally, f 1 and f 2 in the initial and optimal trajectories are nearly identical, respectively. The feeding manipulator can run continuously and periodically under the simulation in ADAMS and experiment in the actual manipulator. Results show that the proposed method can address the current lack of methods to adjust motion positions with the local variable period in the high-speed automobile-panel stamping line.
Author contributions
Yu Luchuan designed and wrote the article. Zhou Shunqing conducted data gathering. Huang Shenquan performed statistical analyses.
Financial support
This research received no specific grant from any funding agency, commercial, or not-for-profit sectors.
Conflicts of interest
The author declares that there is no conflict of interest.