



1 Introduction
First introduced in the 1950s by Anzai [Reference Anzai2] and thoroughly analysed later in the 1960s by Furstenberg [Reference Furstenberg7], Anzai skew products are a class of topological dynamical systems which is broad enough to produce a wide range of ergodic properties depending on the parameters assigning the system.
The starting point to define such systems is a uniquely ergodic system
 $(X_0, \theta )$
, where
 $X_0$
is a compact Hausdorff space and
 $\theta $
a homeomorphism of
 $X_0$
with only one invariant measure
 $\mu _0$
(which is assumed fully supported). If f is any continuous function from
 $X_0$
to
 ${\mathbb T}$
, the one-dimensional torus, we can consider the homeomorphism
 $$ \begin{align*} \Phi_f(x, z):= (\theta(x), f(x)z),\quad (x,z)\in X_0\times{\mathbb T}. \end{align*} $$
acting on the product
 $X_0\times {\mathbb T}$
. The Anzai skew product associated with f is by definition the dynamical system given by the pair
 $(X_0\times {\mathbb T}, \Phi _f)$
. The product measure
 $\mu _0\times m$
, with m being the normalized Lebesgue measure on
 ${\mathbb T}$
, is invariant for
 $\Phi _f$
irrespective of what f is. More interestingly, the ergodicity of
 $\mu _0\times m$
is the same as requiring that
 $\mu _0\times m$
is the only
 $\Phi _f$
-invariant measure. Furthermore, the ergodicity of the product measure can be recast more concretely in terms of the following equations in the unknown function g in
 $L^\infty (X_0, \mu _0)$
:
 $$ \begin{align*} g(\theta(x)) f^n(x)=g(x)\quad\mu_0\mbox{-}\textrm{almost everywhere (a.e.)}, \end{align*} $$
known as the cohomological equations. To be precise, the product measure is ergodic (i.e., extreme in the convex set of all invariant measures) if and only if for every
 $n\neq 0$
the cohomological equations only have the trivial solution
 $g=0$
. It is a deep, highly non-trivial result that the non-existence of non-trivial continuous solutions is equivalent to the minimality (i.e., there are no proper closed invariant subsets) of the system. This yields an interesting, much cited example of a minimal system that nevertheless fails to be uniquely ergodic; see [Reference Katok8, Corollary 12.8] or [Reference Mañé11, Theorem 7.1], or [Reference Robinson14]. In recent years non-commutative versions of the Anzai skew products recalled above have been obtained in the framework of
 $C^{*}$
-algebras and their automorphisms. The earliest of these versions was first considered on the non-commutative
 $2$
-torus in [Reference Osaka and Phillips13], and later studied in [Reference Del Vecchio, Fidaleo, Giorgetti and Rossi4] with a focus on aspects of ergodic theory. It was realized soon after that most of the results on the Anzai skew products on the
 $2$
-torus carry over to the more general non-commutative setting of crossed products, [Reference Del Vecchio, Fidaleo and Rossi5]. In particular, the ergodicity of a distinguished invariant state, which will be recalled later on in this paper, is ruled by the behaviour of certain cohomological equations, whose unknowns are now operators in a von Neumann algebra, which is commutative as long as the crossed product is obtained out of a commutative
 $C^{*}$
-algebra. Moreover, the ergodicity of this state still amounts to the unique ergodicity of the system. Allowing more generality, one is led to consider unique ergodicity with respect to the fixed-point subalgebra as well. This property was first introduced by Abadie and Dykema [Reference Abadie and Dykema1] as a generalization of unique ergodicity where one requires that every state on the fixed-point subalgebra has only one invariant extension to the whole algebra. In [Reference Del Vecchio, Fidaleo and Rossi5] it was shown that, for a skew product, unique ergodicity with respect to the fixed-point subalgebra implies continuity of all solutions to the cohomological equations. The converse was proved to hold only for classical systems, leaving out the case of a general crossed product. One of our original motivations for writing the present paper was to bridge this gap. Another was to answer in our setting a question posed about a decade ago by Abadie and Dykema, [Reference Abadie and Dykema1, Question 3.4]: whether the uniqueness of an invariant conditional expectation onto the fixed-point subalgebra implies unique ergodicity with respect to the fixed-point subalgebra. It turns out that this is the case for skew products, as we prove in Theorem 3.14. This result is worth comparing with the general picture, where the question is in fact answered in the negative, as shown by a counterexample due to D. Ursu (Example 2.1).
With these goals in mind, we have taken this opportunity to further extend our scope by letting a locally compact group G (satisfying a number of mild assumptions), rather than a single automorphism, act on our crossed products. Not only does this generality allow us to consider a wider class of
 $C^{*}$
-dynamical systems, but also, and possibly more importantly, it lays greater emphasis on the interpretation of the cohomological equations as coboundary equations for those
 $1$
-cocycles on G through which the dynamics is assigned. For a comprehensive account in the classical setting of skew-product extension by the action of a locally compact group the reader is referred to [Reference Katok8, Reference Schmidt15].
That said, we can now move on to present our results while describing how the paper is organized. Section 2 acquaints the reader with most of the prerequisites needed to give self-contained proofs of the paper’s results.
Section 2.1 provides a rather quick account of what we deem is strictly necessary to know about the crossed product of a
 $C^{*}$
-algebra by a single automorphism. Section 2.2 contains a detailed treatment of unique ergodicity with respect to the fixed-point subalgebra in our general context of non-commutative
 $C^{*}$
-algebras acted upon by a unimodular, amenable, second-countable locally compact group G. In more detail, Proposition 2.2 is the characterization of unique ergodicity with respect to the fixed-point subalgebra in terms of the pointwise norm convergence of the Cesàro averages, whereas Proposition 2.4 is a general version of von Neumann’s ergodic theorem, where the convergence of the Cesàro averages holds at the Hilbert space level. Although these results might be more or less known or at least easily guessed, their proofs are not entirely trivial, nor are their statements easily found in the literature of the field. Therefore, we have decided to include them in the paper in the hope that they may also serve as a quick yet readable introduction to the topic.
In §3, starting from a uniquely ergodic system
 $({\mathfrak A}, G, \theta )$
, with unique G-invariant state
 $\omega _0$
, and a
 $1$
-cocycle
 $(u_g)_{g\in G}$
of G in
 ${\mathbb T}$
, we define the extended skew product as the action of G on the crossed product
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
through the
 $*$
-automorphisms
 $\Phi _g^u$
given by
 $$ \begin{align*} \Phi_g^u(a):=\theta_g(a),\ \textrm{for all } a\in{\mathfrak A},\quad \Phi_g^u(V):=u_g V, \end{align*} $$
where V is the unitary implementator of
 $\alpha $
, that is,
 $VaV^{*}=\alpha (a)$
for all a in
 ${\mathfrak A}$
. The action of
 $\Phi _g^u$
on the powers of V is given by
 $\Phi _g^u(V^n)= u_g^{(n)}V^n$
, where, for every n in
 ${\mathbb Z}$
,
 $(u_g^{(n)})_{g\in G}$
is a new
 $1$
-cocycle of G which takes account of
 $\alpha $
.
In analogy with the classical case, the state
 $\omega $
on
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
given by
 $$ \begin{align*} \omega(aV^n)=\omega_0(a)\delta_{n, 0},\quad a\in{\mathfrak A},\ n\in{\mathbb Z}, \end{align*} $$
is a distinguished invariant state, which we shall refer to as the canonical invariant state.
In §3.1, we show that two such systems are equivalent, either as topological or measurable systems, if and only if the corresponding
 $1$
-cocycles are cohomologous, with a continuous or a measurable coboundary (Theorem 3.3).
In §3.2, we analyse the fixed-point subalgebra by proving that a strong dichotomy occurs: it is either trivial or isomorphic with
 $C({\mathbb T})$
, the continuous functions on
 ${\mathbb T}$
, Proposition 3.6. Moreover, for the fixed-point subalgebra to be trivial it is necessary and sufficient that none of the cocycles
 $\{(u_g^{(n)})_{g\in G}\colon n\neq 0\}$
is a continuous coboundary (Proposition 3.4). Section 3.2 ends with Theorem 3.8, where unique ergodicity with respect to the fixed-point subalgebra is shown to hold if and only if for every n in
 ${\mathbb Z}$
the
 $1$
-cocycle
 $(u_g^{(n)})_{g\in G}$
is not a measurable non-continuous coboundary, thus solving the problem left open in [Reference Del Vecchio, Fidaleo and Rossi5].
Section 3.3 is devoted to the study of the convex set of all invariant states of the extended skew product. Once again, a strong dichotomy occurs, for this set is either a singleton or affinely homeomorphic with
 ${\mathcal P}({\mathbb T})$
, the set of all Borel probability measures on
 ${\mathbb T}$
(Theorem 3.13). Phrased differently, as soon as the system fails to be uniquely ergodic, that is, some of the
 $1$
-cocycles
 $(u_g^{(n)})_{g\in G}$
are (possibly measurable) coboundaries, its invariant states feature a rich structure, which is morally reminiscent of the fixed-point subalgebra even at the level of the von Neumann algebra generated in the Gelfand–Naimark–Segal (GNS) representation of the canonical invariant state. Finally, Theorem 3.14 completes the characterization of unique ergodicity with respect to the fixed-point subalgebra in terms of invariant conditional expectations onto the fixed-point subalgebra. In particular, this result extends [Reference Del Vecchio, Fidaleo and Rossi6, Theorem 4.2] showing that actually all non-commutative skew products are well behaved in relation to Abadie and Dykema’s problem.
As an outlook for future research, we would like to pose a question: is it true that a non-commutative skew product is minimal in the sense of Longo and Peligrad [Reference Longo and Peligrad10, Definition 2.1], if and only if none of the cocycles
 $\{(u_g^{(n)})_{g\in G}: n\neq 0\}$
is a continuous coboundary? An affirmative answer to this question might yield an example of a non-trivial non-commutative
 $C^{*}$
-dynamical system that is minimal without being uniquely ergodic.
2 Preliminaries
2.1 Crossed products
Throughout the paper, we will make extensive use of the crossed product of a given
 $C^{*}$
-algebra by the action of a single automorphism. Therefore, to keep the exposition as self-contained as possible, we start by recalling what that crossed product is. Given a (unital)
 $C^{*}$
-algebra
 ${\mathfrak A}$
and an automorphism
 $\alpha $
of
 ${\mathfrak A}$
, the universal (or maximal) crossed product of
 ${\mathfrak A}$
by
 $\alpha $
is the universal
 $C^{*}$
-algebra generated by
 ${\mathfrak A}$
and a unitary V such that
 $VaV^{*}=\alpha (a)$
for all a in
 ${\mathfrak A}$
. Such a
 $C^{*}$
-algebra can be shown to exist (see, for example, [Reference Davidson3]) and is denoted by
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
.
By its very definition, the unitary V is actually defined up to a phase, meaning that the one-dimensional torus,
 ${\mathbb T}$
, acts naturally on
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
through the so-called gauge automorphisms
 $\{\alpha _z: z\in {\mathbb T}\}$
, determined by
 $\alpha _z(a)=a$
for all a in
 ${\mathfrak A}$
and
 $\alpha _z(V)=zV$
. In particular, it follows that the spectrum of V is the whole of
 ${\mathbb T}$
.
The
 $C^{*}$
-subalgebra
 ${\mathfrak A}\subset {\mathfrak A}\rtimes _\alpha {\mathbb Z}$
is easily seen to be the invariant subalgebra under the gauge action. Furthermore, by averaging the gauge action one obtains a canonical (faithful) conditional expectation, E, from
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
onto
 ${\mathfrak A}$
. Explicitly, E is defined as
 $E(x):=\int _{\mathbb T} \alpha _z(x)\,dm(z)$
, x in
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
, where m is the normalized Lebesgue measure of
 ${\mathbb T}$
. Note that E is completely determined by
 $E(aV^n)=a\delta _{n,0}$
, for all a in
 ${\mathfrak A}$
and n in
 ${\mathbb Z}$
, where
 $\delta $
is the Kronecker symbol.
The canonical conditional expectation allows for the Fourier expansion in the setting of crossed products. Indeed, it is known that any x in
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
can be written as
 $x=\sum _{k\in {\mathbb Z}} V^kE(V^{-k}x)$
, where the convergence of the series is in norm but in the Cesàro sense [Reference Davidson3, Theorem VIII.2.2].
In the sequel we will need to identify
 $C^{*}({\mathfrak A}, V^n)$
with
 ${\mathfrak A}\rtimes _{\alpha ^n}{\mathbb Z}$
for a fixed integer n. This is possible thanks to the following proposition, whose proof is included in full detail for want of a reference.
Proposition 2.1. For every n in
 ${\mathbb Z}$
, the
 $C^{*}$
-subalgebra
 $C^{*}({\mathfrak A}, V^n)\subset {\mathfrak A}\rtimes _\alpha {\mathbb Z}$
is canonically isomorphic with
 ${\mathfrak A}\rtimes _{\alpha ^n}{\mathbb Z}$
.
Proof. Thanks to the universal property enjoyed by
 ${\mathfrak A}\rtimes _{\alpha ^n}{\mathbb Z}$
, there exists a surjective
 $*$
-homomorphism
 $\Psi \colon {\mathfrak A}\rtimes _{\alpha ^n}{\mathbb Z}\rightarrow C^{*}({\mathfrak A}, V^n)$
such that
 $\Psi (a)=a$
, for all a in
 ${\mathfrak A}$
, and
 $\Psi (W)=V^n$
, where W in
 ${\mathfrak A}\rtimes _{\alpha ^n}{\mathbb Z}$
is the implementator of
 $\alpha ^n$
.
We need to show that
 $\Psi $
is injective. Let x in
 ${\mathfrak A}\rtimes _{\alpha ^n}{\mathbb Z}$
be such that
 $\Psi (x)=0$
. Considering the Fourier expansion of x allows us to rewrite it as
 $x=\sum _{k\in {\mathbb Z}} W^ka_k$
, for some sequence
 $\{a_k: k\in {\mathbb Z}\}\subset {\mathfrak A}$
. Correspondingly
 $\Psi (x)$
, too, can be expanded as
 $\Psi (x)=\sum _{k\in {\mathbb Z}} V^{nk}a_k$
. Now
 $\Psi (x)=0$
is only possible if
 $a_k=0$
for all k in
 ${\mathbb Z}$
by virtue of the uniqueness of the Fourier expansion in
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
. But then
 $x=0$
as well, and we are done.
2.2 General results on
 $C^{*}$
-dynamical systems

By a
 $C^{*}$
-dynamical system we mean a triple
 $({\mathfrak A}, G, \alpha )$
, where
 ${\mathfrak A}$
is a (unital)
 $C^{*}$
-algebra, G a locally compact group, and
 $\alpha : G\rightarrow \mathrm {Aut}({\mathfrak A})$
a group homomorphism. In other words, associated with every g in G there is an automorphism
 $\alpha _g$
of
 ${\mathfrak A}$
such that
 $\alpha _{gh}=\alpha _g\circ \alpha _h$
for all
 $g, h$
in G. Furthermore, as is commonly assumed, we also need to require the following continuity condition: for every a in
 ${\mathfrak A}$
, the map
 $G \ni g\mapsto \alpha _g(a)\in {\mathfrak A}$
is continuous as a function from G with its topology to
 ${\mathfrak A}$
endowed with its norm topology.
Given a
 $C^{*}$
-dynamical system
 $({\mathfrak A}, G, \alpha )$
, a state
 $\omega $
on
 ${\mathfrak A}$
is said to be invariant under the dynamics, or more shortly G-invariant, if
 $\omega \circ \alpha _g=\omega $
for all g in G. The (compact convex) set of all G-invariant states is denoted by
 ${\mathcal S}({\mathfrak A})^G$
.
A
 $C^{*}$
-dynamical system is said to be uniquely ergodic if
 ${\mathcal S}({\mathfrak A})^G$
is a singleton. Phrased differently, unique ergodicity means that the system only has one invariant state. Unique ergodicity is the strongest notion of ergodicity one may consider. For instance, under suitable assumptions on the group G (e.g. amenability), it implies that the fixed-point subalgebra,
 ${\mathfrak A}^G:=\{a\in {\mathfrak A}: \alpha _g(a)=a, g\in G\}$
, is trivial. The property of having a trivial fixed-point subalgebra is often referred to as weak (or topological) ergodicity.
An interesting generalization of unique ergodicity was introduced by Abadie and Dykema in [Reference Abadie and Dykema1], where they consider the action of a single automorphism,
 $G={\mathbb Z}$
, by allowing the fixed-point subalgebra to be non-trivial. To be precise, a
 $C^{*}$
-dynamical system
 $({\mathfrak A}, {\mathbb Z}, \alpha )$
is uniquely ergodic with respect to the fixed-point subalgebra if any state on
 ${\mathfrak A}^{\mathbb Z}$
admits exactly one
 ${\mathbb Z}$
-invariant extension to the whole
 $C^{*}$
-algebra
 ${\mathfrak A}$
. This property can be characterized in a number of ways, the most relevant of which is that it is equivalent to the pointwise convergence in norm of the Cesàro averages; see [Reference Abadie and Dykema1, Theorem 3.2]. As is noted in that paper, the convergence in norm of the Cesàro averages has the important consequence that there exists a unique invariant conditional expectation onto the fixed-point subalgebra, which is of course obtained by taking the limit of the Cesàro averages themselves. In the same paper, Abadie and Dykema raised the question as to whether the uniqueness of such an invariant conditional expectation is enough for unique ergodicity with respect to the fixed-point algebra to hold. The answer in the negative to that problem has recently been found by D. Ursu, who exhibited an example of a classical dynamical system which fails to be uniquely ergodic with respect to the fixed-point subalgebra while featuring a unique conditional expectation. Since this example has not been published but is part of a private communication, we would like to include it below.
Example 2.1. Let
 $X = {\mathbb Z}\bigcup \{-\infty \}\bigcup \{\infty \}$
be the two-point compactification of
 ${\mathbb Z}$
. Let
 $\alpha $
be the ‘shift by 1’ homeomorphism. Note that
 $f\in C(X)$
with
 $f\circ \alpha =f$
implies that f is constant.
Let Y be the space that is obtained by gluing together
 $[0, 1]$
and X, identifying
 $1$
in the former space and
 $-\infty $
in the latter. We may extend
 $\alpha $
to Y by acting trivially on
 $[0, 1]$
. We continue to denote this extension by
 $\alpha $
. Now
 $C[0, 1]$
embeds unitally into
 $C(Y )$
by extending any of its functions f to take the constant value
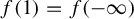 $f(1) =f(-\infty )$
on all of X. Under this embedding, it is clear that
 $C(Y )^\alpha $
=
 $C[0, 1]$
.
We verify that there is a unique conditional expectation
 $E\colon C(Y )\rightarrow C(Y)^\alpha \cong C[0, 1]$
. Let
 $f\in C(Y )$
and let be z in
 $[0, 1)$
be a fixed point. Now let h be any function in
 $C(Y)$
such that
 $h(z)=1$
with h vanishing on X. Note that h sits in
 $C(Y)^\alpha \cong C[0, 1]$
. We have
 $$ \begin{align*} E(f)(z) = E(f)(z) h(z) = E(fh)(z) = (fh)(z) = f(z) h(z) = f(z). \end{align*} $$
Since this is true for any
 $z \in [0, 1)$
, by continuity,
 $E(f)(z) = f(z)$
for
 $z = 1$
in
 $[0, 1]$
as well. In other words, the only conditional expectation is the ‘restriction’ map onto [0, 1]. This is clearly
 $\alpha $
-invariant as well. However, we observe that the two states
 $\delta _{-\infty }$
and
 $\delta _\infty $
are two different
 $\alpha $
-invariant extensions of the state
 $\delta _1$
on
 $C[0, 1]$
.
In order to deal with our skew-product dynamical systems, we need to generalize Abadie and Dykema’s characterization of unique ergodicity with respect to the fixed-point subalgebra so as to cover a wider class of groups. To be precise, henceforth we will be working under the assumption that G is a unimodular, amenable, second-countable locally compact group. We will denote by
 $\mu _G$
its (bi-invariant) Haar measure. The hypotheses made on the group guarantee that G possesses a two-sided Følner sequence
 $\{F_n: n\in {\mathbb N}\}$
; see [Reference Ornstein and Weiss12, §1.1, Proposition 2]. This means that there exists a sequence of compact subsets
 $F_n\subset G$
, n in
 ${\mathbb N}$
, such that
 $\mu _G(F_n)>0$
for all
 $n\in \mathbb {N}$
and such that for every h in G one has
 $\lim _{n\rightarrow \infty } ({\mu _G(F_n\Delta hF_n)}/{\mu _G(F_n)}) =0$
and
 $\lim _{n\rightarrow \infty } ({\mu _G(F_n\Delta F_nh)})/({\mu _G(F_n)}) = 0$
, where
 $\Delta $
denotes the symmetric difference between sets.
Given a
 $C^{*}$
-dynamical system
 $({\mathfrak A}, G, \alpha )$
, for every a in
 ${\mathfrak A}$
, we define the sequence
 $\{M_n(a): n\in {\mathbb N}\}$
of its Cesàro averages as
 $$ \begin{align*} M_n(a):=\frac{1}{\mu_G(F_n)}\int_{F_n}\alpha_g(a)\,d\mu_G(g), \end{align*} $$
where
 $\{F_n: n\in {\mathbb N}\}$
is any (two-sided) Følner sequence. The integral is understood in the sense of Bochner and is well defined thanks to the continuity of the function
 $G \ni g\mapsto \alpha _g(a)\in {\mathfrak A}$
; see, for example, [Reference Yosida16, Theorem 1, §5, Ch. V].
Note that, for each n in
 ${\mathbb N}$
,
 ${\mathfrak A}\ni a\mapsto M_n(a)\in {\mathfrak A}$
defines a bounded linear map from
 ${\mathfrak A}$
to itself, with
 $\|M_n\|\leq 1$
for all n.
That said, we are ready to state the announced generalization of Abadie and Dykema’s characterization of unique ergodicity with respect to the fixed-point subalgebra in the general framework of group actions on non-commutative
 $C^{*}$
-algebras.
Proposition 2.2. For a
 $C^{*}$
-dynamical system
 $(G, \alpha , {\mathfrak A})$
with G as above, the following assertions are equivalent.
-
(i) Every state on
${\mathfrak A}^G$
has a unique G-invariant extension to
${\mathfrak A}$
. -
(ii) For every a in
${\mathfrak A}$
,
$M_n(a)$
converges in norm to some (invariant) element in
${\mathfrak A}$
.


Proof. For the implication (ii)
 $\,\Rightarrow \,$
(i), the equality
 $\omega (a)=\omega (M_n(a))$
, a in
 ${\mathfrak A}$
and n in
 ${\mathbb N}$
, which holds for any invariant state
 $\omega $
, shows that
 $\omega $
is uniquely determined by its restriction to
 ${\mathfrak A}^G$
. The implication is thus proved since it is a standard fact that any state on
 ${\mathfrak A}^G$
can be extended to a G-invariant state on
 ${\mathfrak A}$
thanks to amenability of G.
As for the reverse implication, we start by observing that (i) implies that any bounded linear functional on
 ${\mathfrak A}^G$
has a unique bounded
 $\alpha $
-invariant extension to the whole of
 ${\mathfrak A}$
; cf. [Reference Abadie and Dykema1, Observation 3.1]. We aim to prove that the linear subspace
 $Y:={\mathfrak A}^G+ \mathrm {span}\{a-\alpha _h(a): a\in {\mathfrak A}, h\in G\}$
is norm dense in
 ${\mathfrak A}$
. To this end, by the Hahn–Banach theorem it is enough to show that if a bounded linear functional vanishes on Y, then it is zero on
 ${\mathfrak A}$
. If
 $\varphi $
is any such functional, then
 $\varphi $
is zero on
 ${\mathfrak A}^G$
and is
 $\alpha $
-invariant as well. But then
 $\varphi $
must be zero on
 ${\mathfrak A}$
by the unique extension property.
We next show that (ii) holds for
 $a=b-\alpha _h(b)$
, with b in
 ${\mathfrak A}$
, for a fixed h in G. We do this by showing that for such elements a the corresponding sequence
 $\{M_n(a): n\in {\mathbb N}\}$
is Cauchy:
 $$ \begin{align*} &\|M_n(b-\alpha_h(b))- M_{n+k}(b-\alpha_h(b))\|\\ &\quad =\bigg\|\frac{1}{\mu_G(F_n)}\int_{F_n}(\alpha_g(b-\alpha_h(b)))\,d\mu_G(g)- \frac{1}{\mu_G(F_{n+k})}\int_{F_{n+k}}(\alpha_g(b-\alpha_h(b)))\,d\mu_G(g)\bigg\|\\ &\quad \leq\bigg(\frac{\mu_G(F_n\Delta F_nh)}{\mu_G(F_n)}+\frac{\mu_G(F_{n+k}\Delta F_{n+k}h)}{\mu_G(F_{n+k})}\bigg)\|b\|\leq \varepsilon \end{align*} $$
for all k in
 ${\mathbb N}$
as soon as
 $n\geq N_\varepsilon $
, where
 $N_\varepsilon $
is such that
 ${\mu _G(F_l\Delta F_lh)}/{\mu _G(F_l)} \leq {\varepsilon }/{2\|b\|}$
for all
 $l\geq N_\varepsilon $
, and such
 $N_\varepsilon $
exists by definition of a Følner sequence.
By linearity of the average operators
 $M_n$
, condition (ii) holds for all a in Y.
The full conclusion is reached thanks to the density of Y in
 ${\mathfrak A}$
by an
 ${\varepsilon }/{3}$
-argument. Let a be in
 ${\mathfrak A}$
and let b be in Y with
 $\|a-b\|\leq {\varepsilon }/{3}$
. Then we have
 $$ \begin{align*} &\|M_n(a) - M_{n+k}(a)\|\\ &\quad \leq\|M_n(a) - M_n(b)\|+\|M_n(b) - M_{n+k}(b)\|+\|M_{n+k}(b) - M_{n+k}(a)\|\\ &\quad \leq\frac{2\varepsilon}{3}+\|M_n(b) - M_{n+k}(b)\|\leq \varepsilon, \end{align*} $$
for all k in
 ${\mathbb N}$
and
 $n\geq N_\varepsilon $
, where
 $N_\varepsilon $
in
 ${\mathbb N}$
is such that
 $n\geq N_\varepsilon $
implies
 $\|M_n(b) - M_{n+k}(b)\|\leq {\varepsilon }/{3}$
. The proof is thus complete.
At this point the characterization of unique ergodicity, which is a more or less known fact (cf. [Reference Longo and Peligrad10, Proposition 2.4]), is an easy application of Proposition 2.2.
Corollary 2.3. A
 $C^{*}$
-dynamical system
 $(G, \alpha , {\mathfrak A})$
with G as above is uniquely ergodic with unique G-invariant state
 $\omega $
if and only if for all a in
 ${\mathfrak A}$
one has
 $\lim _{n\rightarrow \infty }M_n(a)=\omega (a)1$
in norm.
Proof. It is enough to show that unique ergodicity implies
 ${\mathfrak A}^G={\mathbb C}$
. If
 ${\mathfrak A}^G$
is not trivial, then there exist at least two different states
 $\omega _1, \omega _2$
on it. Denote by
 $\widetilde {\omega }_i$
any extension of
 $\omega _i$
,
 $i=1, 2$
, to the whole of
 ${\mathfrak A}$
. Consider the two sequences of states
 $\{({1}/{\mu _G(F_n))} \int _{F_n}\widetilde {\omega }_i\circ \alpha _g \,d\mu _G(g): n\in {\mathbb N}\}$
,
 $i=1, 2$
. By compactness, for
 $i=1, 2$
, there exists
 $\varphi _i$
, which is an accumulation point of
 $\{({1}/{\mu _G(F_n))}\int _{ F_n}\widetilde {\omega }_i\circ \alpha _g \,d\mu _G(g): n\in {\mathbb N}\}$
. By construction
 $\varphi _1$
and
 $\varphi _2$
are both G-invariant, and yet they do not agree on
 ${\mathfrak A}^G$
, hence
 $\varphi _1\neq \varphi _2$
.
The final proposition of this section is a von Neumann ergodic theorem tailored to our framework. Although it is likely to be a known result, we include a complete proof all the same, for want of a reference. Before stating it, let us establish some notation.
Given a G-invariant state
 $\omega $
, for all g in G, we denote by
 $V_g^\omega $
the unitary implementator of
 $\alpha _g$
on the GNS Hilbert space
 ${\mathcal H}_\omega $
, that is,
 $$ \begin{align} V_g^\omega\pi_\omega(a)\xi_\omega:=\pi_\omega(\alpha_g(a))\xi_\omega\quad\textrm{for all } a \in {\mathfrak A}. \end{align} $$
By definition
 $V_g^\omega \pi _\omega (a)(V_g^\omega )^{*}=\pi _\omega (\alpha _g(a))$
, for all a in
 ${\mathfrak A}$
and g in G. We denote by
 ${\mathcal H}_\omega ^G$
the closed subspace of all G-invariant vectors of
 ${\mathcal H}_\omega $
, that is,
 ${\mathcal H}_\omega ^G:=\{x\in {\mathcal H}_\omega : V_g^\omega x=x, \textrm {for all}\, g\in G\}$
, and by
 $E_\omega $
the orthogonal projection of
 ${\mathcal H}_\omega $
onto
 ${\mathcal H}_\omega ^G$
.
Now, as is easy to verify, the continuity of
 $G \ni g\mapsto \alpha _g(a)\in {\mathfrak A}$
(where a is any fixed element of
 ${\mathfrak A}$
) implies that, for any invariant state
 $\omega $
on
 ${\mathfrak A}$
, the map
 $G\ni g\mapsto V_g^\omega \in {\mathcal B}({\mathcal H}_\omega )$
is a strongly continuous unitary representation of G, that is, for any vector x in
 ${\mathcal H}_\omega $
, the function
 $G\ni g\mapsto V_g^\omega x\in {\mathcal H}_\omega $
is norm continuous. We are now ready to state our version of von Neumann’s ergodic theorem.
Proposition 2.4. Let
 $({\mathfrak A}, G, \alpha )$
be a
 $C^{*}$
-dynamical system with G as above and let
 $\omega $
be in
 ${\mathcal S}({\mathfrak A})^G$
. Then for any x in
 ${\mathcal H}_\omega $
one has
 $$ \begin{align*} \lim_{n\rightarrow\infty} \frac{1}{\mu_G(F_n)}\int_{F_n} V_g^\omega x\,d\mu_G(g)= E_\omega x, \end{align*} $$
where the convergence holds in norm and
 $\{F_n: n\in {\mathbb N}\}$
is any Følner sequence for G.
Proof. If x sits in
 ${\mathcal H}_\omega ^G$
, then
 $({1}/{\mu _G(F_n))}\int _{F_n} V_g^\omega x\,d\mu _G(g)=x$
for all n, and there is nothing to prove. The result will follow if we show that for every x in
 $({\mathcal H}_\omega ^G)^\perp $
one has
 $$ \begin{align*} \lim_{n\rightarrow\infty} \frac{1}{\mu_G(F_n)}\int_{F_n} V_g^\omega x\,d\mu_G(g)= 0.\end{align*} $$
To this end, note that
 $({\mathcal H}_\omega ^G)^\perp =\overline {\operatorname {span}}\{\mathrm {Ran}(I-V_h^\omega ): h\in G\}$
. Thus linearity and a standard approximation argument enable us to consider x of the form
 $x=(I-V_h^\omega )y$
for some h in G and y in
 ${\mathcal H}_\omega $
. For such an x we have
 $$ \begin{align*} &\frac{1}{\mu_G(F_n)}\int_{F_n} V_g^\omega x\,d\mu_G(g)= \frac{1}{\mu_G(F_n)}\int_{F_n} V_g^\omega (I-V_h^\omega)y\,d\mu_G(g)\\ &\quad =\frac{1}{\mu_G(F_n)}\int_{F_n} V_g^\omega y\,d\mu_G(g)-\frac{1}{\mu_G(F_n)}\int_{F_n} V_{gh}^\omega y\,d\mu_G(g)\\ &\quad =\frac{1}{\mu_G(F_n)}\int_{F_n} V_g^\omega y\,d\mu_G(g)-\frac{1}{\mu_G(F_n)}\int_{F_nh} V_g^\omega y\,d\mu_G(g)\\ &\quad =\frac{1}{\mu_G(F_n)}\int_{F_n\setminus F_nh} V_g^\omega y\,d\mu_G(g)-\frac{1}{\mu_G(F_n)}\int_{F_n h\setminus F_n} V_g^\omega y\,d\mu_G(g), \end{align*} $$
hence
 $$ \begin{align*} \bigg\|\frac{1}{\mu_G(F_n)}\int_{F_n} V_g^\omega x\,d\mu_G(g)\bigg\| \leq \frac{\mu_G(F_n\Delta F_nh)}{\mu_G(F_n)}\|y\|\rightarrow 0 \end{align*} $$
as n goes to
 $\infty $
thanks to the definition of a Følner sequence.
Remark 2.5. The above result continues to hold under the milder assumption that G is only amenable.
3 Non-commutative skew-product extensions
We start with a
 $C^{*}$
-dynamical system
 $({\mathfrak A}, G, \theta )$
, where
 ${\mathfrak A}=C(X_0)$
(with
 $X_0$
being a metrizable compact space) is a commutative
 $C^{*}$
-algebra, G a unimodular, amenable, second-countable locally compact group, and
 $\theta : G\rightarrow \mathrm {Aut}({\mathfrak A})$
a continuous group homomorphism. From now on we will always work under the assumption that
 $({\mathfrak A}, G, \theta )$
is uniquely ergodic with unique invariant state
 $\omega _0$
(
 $\omega _0(f)=\int _{X_0} f\,d\mu _0$
, f in
 $C(X_0)$
, for a unique probability Borel measure
 $\mu _0$
).
By a continuous
 $1$
-cocycle on G we will always mean a continuous function
 $u: G\times X_0\rightarrow {\mathbb T}$
such that
 $$ \begin{align} u(gh, x)=u(h, \theta_{g^{-1}}(x))u(g, x)\quad\textrm{for all } g, h\,\in G, x\in X_0. \end{align} $$
For any fixed g in G, we can think of the function
 $X\ni x\mapsto u(g, x)\in {\mathbb T}$
as a unitary element of the
 $C^{*}$
-algebra
 ${\mathfrak A}=C(X_0)$
, which we will henceforth denote by
 $u_g$
. In terms of
 $u_g$
(3.1) can be rewritten as
 $$ \begin{align} u_{gh}=\theta_g(u_h)u_g\quad \textrm{for all } g, h\,\in G. \end{align} $$
Note that if
 $u=(u_g)_{g\in G}$
and
 $v=(v_g)_{g\in G}$
are
 $1$
-cocycles, then
 $uv^{*}=(u_gv_g^{*})_{g\in G}$
is still a
 $1$
-cocycle.
For a given automorphism (homeomorphism)
 $\alpha $
of
 ${\mathfrak A}=C(X_0)$
we consider the universal crossed product
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
. As of now, we will assume that
 $\alpha $
commutes with the action of G,
 $\alpha \circ \theta _g=\theta _g\circ \alpha $
, for all g in G. Let
 $u=(u_g)_{g\in G}$
be a
 $1$
-cocycle with respect to the action
 $\theta $
. For every g in G, the universal property of the crossed product allows us to define a unique automorphism
 $\Phi _g^u$
of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
, whose action on the generators is
 $$ \begin{align*} \Phi_g^u(a):=\theta_g(a)\quad \textrm{for all } a\in{\mathfrak A},\quad \Phi_g^u(V):=u_g V. \end{align*} $$
Furthermore, thanks to (3.2) one can readily see that
 $\Phi _{gh}^u=\Phi _g^u\circ \Phi _h^u$
. We will denote the
 $C^{*}$
-dynamical system thus obtained by
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
. Compounding
 $\omega _0$
with the canonical conditional expectation, E, onto
 ${\mathfrak A}$
yields a distinguished G-invariant state
 $\omega :=\omega _0\circ E$
. The G-invariance of
 $\omega $
follows at once from the equality
 $\omega (aV^k)=\omega _0(a)\delta _{k, 0}$
, for all a in
 ${\mathfrak A}$
and k in
 ${\mathbb Z}$
.
Finally, for every g in G we denote by
 $\widetilde {\Phi }^u_g$
the action of
 $\Phi ^u_g$
at the level of von Neumann algebra
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
, namely
 $\widetilde {\Phi }^u_g(T)=V_g^\omega T (V_g^\omega )^{*} $
, for all T in
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
, where
 $V_g^\omega $
is the unitary implementator of
 $\Phi _g^u$
which was defined in equation (2.1).
Example 3.1. The general construction above applies in particular to the non-commutative (irrational)
 $2$
-torus
 $\mathbb {A}_\alpha $
(the universal
 $C^{*}$
-algebra generated by two unitaries U and V subject to the commutation rule
 $UV= e^{2\pi i\alpha }VU$
) as soon as this is seen as the crossed product of
 $C({\mathbb T})$
by the action of the homeomorphism
 $\alpha $
given by the rotation
 $\alpha (z)=e^{2\pi i\alpha }z$
, z in
 ${\mathbb T}$
, where with a slight abuse of notation
 $\alpha $
denotes both the homeomorphism and the rotation angle (
 $\alpha $
lies in
 ${\mathbb R}\setminus {\mathbb Q}$
).
We take
 $G={\mathbb Z}$
, which means we need only define an automorphism acting on
 $\mathbb {A}_\alpha $
. The automorphism
 $\theta $
on
 $C({\mathbb T})$
from which we start is the one corresponding to the rotation
 $\theta (z)=e^{2\pi i\theta }z$
, z in
 ${\mathbb T}$
, where again
 $\theta $
is assumed irrational. Therefore, the dynamical system
 $(C({\mathbb T}), \theta )$
is uniquely ergodic with its unique invariant measure given by the normalized Lebesgue measure m on
 ${\mathbb T}$
. Now, since
 ${\mathbb Z}$
is a singly generated group, defining a
 $1$
-cocycle on
 ${\mathbb Z}$
amounts to choosing a unitary u in
 $C({\mathbb T})$
. Indeed, if we denote by
 $\Phi ^u_1$
the automorphism on the non-commutative
 $2$
-torus determined by
 $\Phi ^u_1(U)=e^{2\pi i\theta } U$
and
 $\Phi ^u_1(V)=uV$
, then, for each integer n,
 $\Phi ^u_n:= (\Phi ^u_1)^n$
acts on V,
 $$ \begin{align*} \Phi^u_n(V)=\begin{cases} V, &n=0,\\[1ex] u\theta(u)\ldots \theta^{n-1}(u) V, & n>0, \\[1ex] \theta^{n}(u^{*})\theta^{n+1}(u^{*})\ldots\theta^{-1}(u^{*})V, & n<0, \end{cases} \end{align*} $$
which allows us to identify the
 $1$
-cocycle
 $(u_n)_{n\in {\mathbb Z}}$
on
 ${\mathbb Z}$
at once.
3.1 Classification in terms of cocycles
The present section is devoted to the classification of our skew-product systems up to a natural notion of conjugacy. We actually consider two such notions, depending on whether our emphasis lies on topological or measurable dynamics. We start by giving a couple of definitions.
Definition 3.1. A
 $1$
-cocycle
 $u=(u_g)_{g\in G}$
is a continuous (or
 $L^\infty $
) coboundary if there exists a continuous (or in
 $L^\infty (X_0,\mu _0)$
) function (known as a
 $0$
-cocycle)
 $w\colon X\rightarrow {\mathbb T}$
such that
 $$ \begin{align*} u_g=\theta_g(w^{*})w\quad \textrm{for all } g\in G. \end{align*} $$
Two
 $1$
-cocycles
 $u=(u_g)_{g\in G}$
and
 $v=(v_g)_{g\in G}$
are
 $C^{*}$
(or
 $W^{*}$
) cohomologous if the
 $1$
-cocycle
 $uv^{*}=(u_gv_g^{*})_{g\in G}$
is a continuous (or
 $L^\infty $
) coboundary.
Definition 3.2. We say that two skew products
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
and
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^v)$
are
 $C^{*}$
-conjugate if there exists a
 $*$
-isomorphism
 $\Psi $
of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
such that
 $\Psi (a)=a$
for all a in
 ${\mathfrak A}$
, and
 $\Phi ^u_g\circ \Psi =\Psi \circ \Phi ^v_g$
for all g in G.
Analogously,
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
and
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^v)$
are
 $W^{*}$
-conjugate if there exists a
 $*$
-isomorphism
 $\Psi $
of
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
such that
 $\Psi (\pi _\omega (a))=\pi _\omega (a)$
for all a in
 ${\mathfrak A}$
, and
 $\widetilde {\Phi }^u_g\circ \Psi =\Psi \circ \widetilde { \Phi }^v_g$
for all g in G.
We are now ready to state the result on the classification of our systems.
Theorem 3.3. Let
 $X_0$
be an infinite compact Hausdorff space and let
 $\alpha $
be a uniquely ergodic automorphism of
 $X_0$
with a unique invariant measure
 $\mu _0$
which is fully supported. Two skew products
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
and
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^v)$
, where
 ${\mathfrak A}:=C(X_0)$
, are
 $C^{*}$
(or
 $W^{*}$
) conjugate if and only if the corresponding
 $1$
-cocycles
 $u=(u_g)_{g\in G}$
,
 $v=(v_g)_{g\in G}$
are
 $C^{*}$
(or
 $W^{*}$
) cohomologous.
Proof. We start by dealing with the case when one of the two systems is trivial, say
 $v=(v_g)_{g\in G}=1$
, namely
 $v_g=1$
for all g in G. If
 $v=1$
, then
 $u=(u_g)_{g\in G}$
is a coboundary, that is there exists a unitary function
 $w: X\rightarrow {\mathbb T}$
satisfying
 $u_g=\theta _g(w^{*})w$
for all g in G.
Suppose first that w is a continuous function. By universality of the crossed product, the map
 $\Psi (a):=a$
, a in
 ${\mathfrak A}$
,
 $\Psi (V):=wV$
extends to an endomorphism of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
which is seen at once to be an automorphism. We next show that the equality
 $\Psi \circ \Phi _g^1= \Phi _g^u\circ \Psi $
holds for all g in G. To this end, it is enough to check the equality on V (as it obviously holds for all a in
 ${\mathfrak A}$
), which is done below:
 $$ \begin{align*} \Psi\circ\Phi_g^1(V)=wV=\theta_g(w)u_gV=\Phi_g^u\circ\Psi(V). \end{align*} $$
Conversely, if
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
and
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^1)$
are
 $C^{*}$
-conjugate through an automorphism
 $\Psi $
such that
 $\Psi \circ \Phi _g^1= \Phi _g^u\circ \Psi $
, then
 $\Psi (V)=wV$
for some w in
 ${\mathfrak A}$
thanks to Lemma A.5. The same computation as above shows that imposing the intertwining relation
 $\Psi \circ \Phi _g^1= \Phi _g^u\circ \Psi $
on V implies that w satisfies
 $u_g=\theta _g(w^{*})w$
for all g in G, hence u is continuous coboundary.
Suppose now that the solution w is only measurable, that is, w sits in
 $\pi _{\omega _0}({\mathfrak A})"\cong L^\infty (X_0, \mu _0)$
and satisfies
 $\widetilde {\theta }_g(w)u=w$
for all g in G. Our next aim is to show that there exists an automorphism
 $\Psi $
of the von Neumann algebra
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
such that
 $\Psi (\pi _\omega (a))=\pi _\omega (a)$
, a in
 ${\mathfrak A}$
, and
 $\Psi (\pi _\omega (V))=w\pi _\omega (V)$
. To begin with, by universality of the crossed product there does exist an injective
 $*$
-homomorphism
 $\Psi _o$
from
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})$
to
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
such that
 $\Psi _o(\pi _\omega (a))=\pi _\omega (a)$
, a in
 ${\mathfrak A}$
, and
 $\Psi _o(\pi _\omega (V))=w\pi _\omega (V)$
. Now denote by
 $\widetilde {\omega }$
the vector state of
 ${\mathcal B}({\mathcal H}_\omega )$
associated with
 $\xi _\omega $
. We next show that the equality
 $\widetilde {\omega }\circ \Psi _o=\widetilde {\omega }$
holds on
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})$
. Indeed, for all a in
 ${\mathfrak A}$
and k in
 ${\mathbb Z}$
, we have
 $$ \begin{align*} \widetilde{\omega}\circ\Psi_o\, (\pi_\omega(aV^k))=\widetilde{\omega}(\pi_\omega(a) (w\pi_\omega(V))^k)=\delta_{k, 0}\widetilde{\omega}(\pi_\omega(a))=\widetilde{\omega}(\pi_\omega(aV^k)). \end{align*} $$
This allows us to define an isometry
 $U_o$
on the dense subspace
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})\xi _\omega \subset {\mathcal H}_\omega $
as
 $$ \begin{align*} U_o \bigg(\sum_k \pi_\omega(a_kV^k)\xi_\omega\bigg):=\Psi_o\bigg(\sum_k \pi_\omega(a_kV^k)\bigg)\xi_\omega. \end{align*} $$
We denote by U the extension of
 $U_o$
to the whole Hilbert space
 ${\mathcal H}_\omega $
and note that U is actually a unitary whose inverse can be obtained by performing the above construction again with w replaced by
 $w^{*}$
.
By construction the restriction of
 $\mathrm {ad}(U)$
to
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})$
coincides with
 $\Psi _o$
. Therefore, the von Neumann algebra
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
is invariant under
 $\mathrm {ad}(U)$
as well, and the restriction of
 $\mathrm {ad}(U)$
to
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
provides an injective homomorphism
 $\Psi $
of
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
into itself, which is surjective because
 $\Psi (w^{*}V)=V$
. Finally, the intertwining relation
 $\Psi \circ \widetilde {\Phi }_g^1=\widetilde {\Phi }_g^ u\circ \Psi $
, for all g in G, can be verified exactly as above.
The implication ‘
 $W^{*}$
-conjugacy
 $\,\Rightarrow \, u=(u_g)_{g\in G}$
is a
 $L^\infty $
-coboundary’ can be proved exactly as in the case of
 $C^{*}$
-conjugacy by applying Lemma A.6.
The general case can be dealt with by the foregoing analysis in the following way. We now know that the
 $1$
-cocycles
 $u=(u_g)_{g\in g}$
and
 $v=(v_g)_{g\in G}$
are
 $C^{*}$
(or
 $W^{*}$
) cohomologous if and only if
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^1)$
and
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^{uv^{*}})$
are
 $C^{*}$
(or
 $W^{*}$
) conjugate, that is, if there exists an automorphism
 $\Psi $
of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
(or
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
) such that
 $\Psi \circ \Phi _g^1=\Phi _g^{uv^{*}}\circ \Psi $
(or
 $\Psi \circ \widetilde {\Phi }_g^1=\widetilde {\Phi }_g^{uv^{*}}\circ \Psi $
) for all g in G. Now
 $\Psi (V)=wV$
(or
 $\Psi (\pi _\omega (V))=w\pi _\omega (V)$
) with w in
 ${\mathfrak A}$
(or w in
 $\pi _{\omega }({\mathfrak A})"$
) satisfying
 $\theta _g(w)uv^{*}=w$
(or
 $\widetilde {\theta }_g(w)uv^{*}=w$
) for all g in G. The conclusion is arrived at by verifying that
 $\Psi $
also intertwines
 $\Phi _g^u$
and
 $\Phi _g^v$
for all g in G, that is,
 $\Psi \circ \Phi _g^v=\Phi _g^u\circ \Psi $
for all g in G, As usual, this equality need only be checked on V:
 $$ \begin{align*} \Psi\circ\Phi_g^v\,(V)&=\Psi(v_gV)=v_gwV=v_g\theta_g(w)u_gv_g^{*}V\\ &=\theta_g(w)u_gV=\Phi_g^u\circ\Psi\, (V), \end{align*} $$
and we are done. The counterpart in the
 $W^{*}$
setting is entirely analogous.
3.2 Weak ergodicity and ergodicity with respect to the fixed-point subalgebra
This section addresses the study of the main ergodic properties a skew-product system may enjoy. In particular, weak ergodicity, unique ergodicity and unique ergodicity with respect to the fixed-point subalgebra can all be characterized in terms of coboundaries.
To state our results, we first need to recall that, given a
 $1$
-cocycle
 $u=(u_g)_{g\in G}$
of G, it is possible to define a family of
 $1$
-cocycles as
 $$ \begin{align*} u_g^{(n)}=\begin{cases} I,& n=0,\\[1ex] u_g\alpha(u_g)\ldots \alpha^{n-1}(u_g), & n>0, \\[1ex] \alpha^{n}(u_g^{*})\alpha^{n+1}(u_g^{*})\ldots\alpha^{-1}(u_g^{*}), & n<0. \end{cases} \end{align*} $$
Note that, for any fixed g in G,
 $(u_g^{(n)})_{n\in {\mathbb Z}}$
is a
 ${\mathbb Z} 1$
-cocycle with respect to the action of
 $\alpha $
. Furthermore, by a straightforward induction on n we see that
 $$ \begin{align*} \Phi_g^u(V^n)= u_g^{(n)}V^n,\quad g\in G, n\in{\mathbb Z}. \end{align*} $$
As we show below, for weak ergodicity to occur it is necessary and sufficient that the so-called cohomological equations at the
 $C^{*}$
-algebra level do not have non-trivial solutions.
Proposition 3.4. The
 $C^{*}$
-dynamical system
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
is weakly ergodic if and only if the
 $1$
-cocycle
 $(u_g^{(n)})_{g\in G}$
is not a continuous coboundary for every n in
 ${\mathbb Z}\setminus \{0\}$
.
In other words,
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
is weakly ergodic if and only if for every
 $n\in {\mathbb Z}$
with
 $n\neq 0$
the equation in the unknown a in
 ${\mathfrak A}$
,
 $$ \begin{align*} \theta_g(a)u_g^{(n)}=a \quad \textrm{for all } g\in G, \end{align*} $$
has only the trivial solution
 $a=0$
.
Proof. Recall that any x in the crossed product
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
can be expanded as
 $x=\sum _n \alpha ^{-n} (E(V^{-n}x))V^n$
, where the convergence of the series is understood in the norm topology in the Cesàro sense. This allows us to study the fixed-point equation
 $\Phi _g^u(x)=x$
, g in G, for x of the form
 $aV^n$
, for some a in
 ${\mathfrak A}$
and n in
 ${\mathbb Z}$
. For such an x, the fixed-point equation
 $\Phi _g^u(aV^n)=aV^n$
, g in G, becomes
 $\theta _g(a)u_g^{(n)}V^n=aV^n$
, which is satisfied if and only if
 $\theta _g(a)u_g^{(n)}=a$
.
Now if
 $a\in {\mathfrak A}$
is a non-trivial solution of
 $\theta _g(a)u_g^{(n)}=a$
, for all
 $g\in G$
, then
 $w:= {|a|}/{\|a\|}$
satisfies
 $\theta _g(w)=w$
for all g in G, hence
 $w=1$
by ergodicity. This shows that if
 $\theta _g(a)u_g^{(n)}=a$
has non-trivial solution, then there is always a unitary solution, that is,
 $(u_g^{(n)})_{g\in G}$
is a continuous coboundary.
Finally, the conclusion is arrived at by noting that for
 $n=0$
the equation is
 $\theta _g(a)=a$
for all g in G, which is satisfied only by multiples of the identity again thanks to ergodicity of
 $({\mathfrak A}, G, \theta )$
.
In the sequel, the equations
 $\theta _g(a)u_g^{(n)}=a$
will be referred to as the
 $C^{*}$
-cohomological equations and their solutions will be called continuous solutions.
Define
 ${\mathbb Z}_u:=\{n\in {\mathbb Z}: (u_g^{(n)})_{g\in G}\,\,\textrm {is a continuous coboundary}\}.$
Proposition 3.5.
 ${\mathbb Z}_u$
is a subgroup of
 ${\mathbb Z}$
, hence
 ${\mathbb Z}_u=m_0{\mathbb Z}$
for some (possibly zero) natural
 $m_0$
.
Moreover, for every n in
 ${\mathbb Z}_u$
the continuous
 $0$
-cocycle that determines the coboundary
 $(u_g^{(n)})_{g\in G}$
is unique up to a phase.
Proof. The group property follows exactly as in [Reference Del Vecchio, Fidaleo and Rossi5, Proposition 10.2]. The second part of the statement amounts to showing that the set of all solutions of
 $\theta _g(a)u_g^{(n)}=a$
, g in G, is of the form
 $\{\unicode{x3bb} w_n: \unicode{x3bb} \in {\mathbb C}\}$
, where
 $w_n$
is a unitary solution of the equation, and this follows again by ergodicity of the measure
 $\mu _0$
.
At this point, we are in a position to prove that the fixed-point subalgebra is always commutative irrespective of the cocycle
 $(u_g)_{g\in G}$
. More precisely, the fixed-point subalgebra is either trivial or isomorphic with
 $C({\mathbb T})$
.
Proposition 3.6. If the
 $C^{*}$
-dynamical system
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
is not weakly ergodic, then the fixed-point subalgebra
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z})^G$
is isomorphic with
 $C({\mathbb T})$
.
Proof. By Propositions 3.4 and 3.5, the fixed-point subalgebra coincides with the subalgebra generated by the unitary
 $w_{m_0}V^{m_0}$
, where
 $w_{m_0}$
is the unique (up to phase) unitary such that
 $\theta _g(w_{m_0})u_g^{(m_0)}=w_{m_0}$
. To show this, take the
 $C^{*}$
-subalgebra of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
generated by
 ${\mathfrak A}$
and
 $V^{m_0}$
. By Proposition 2.1 this is isomorphic with the universal crossed product
 ${\mathfrak A}\rtimes _{\alpha _{m_0}}{\mathbb Z}$
. The universal property of the crossed product allows us to consider a
 $*$
-endomorphism
 $\Psi $
of
 $C^{*}(a, V^{m_0})$
uniquely determined by
 $\Psi (a)=a$
, for all a in
 ${\mathfrak A}$
, and
 $\Psi (V^{m_0})=w_{m_0}V^{m_0}$
. Now
 $\Psi $
is a
 $*$
-isomorphism with inverse
 $\Psi ^{-1}(a)=a$
, for all a in
 ${\mathfrak A}$
, and
 $\Psi ^{-1}(V^{m_0})=w_{m_0}^{*}V^{m_0}$
. The conclusion is now reached by observing that the restriction of
 $\Psi $
to
 $C^{*}(V^{m_0})\cong C({\mathbb T})$
realizes a
 $*$
-isomorphism between
 $C^{*}(V^{m_0})$
and
 $C^{*}(w_{m_0}V^{m_0})$
.
As we did in §2.2, we denote by
 $V_g^\omega $
the unitary that implements
 $\Phi _g^u$
on the GNS representation of the crossed product
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
of the state
 $\omega $
.
The Hilbert space
 ${\mathcal H}_\omega $
of the GNS representation of our distinguished state
 $\omega $
was shown in [Reference Del Vecchio, Fidaleo and Rossi5, Lemma 8.3] to decompose into a direct sum of the type
 $\mathcal {H}_\omega =\oplus _{n\in \mathbb {Z}} \mathcal {H}_n$
, with
 ${\mathcal H}_0:=[\pi _\omega ({\mathfrak A})\xi _\omega ]\cong {\mathcal H}_{\omega _0}$
and
 ${\mathcal H}_n:=\pi _\omega (V)^n[\pi _\omega ({\mathfrak A})\xi _\omega ]$
for all
 $n\neq 0$
. Finally, we denote by
 $V_g^{\omega _0}$
the unitary on
 ${\mathcal H}_{\omega _0}$
implementing
 $\theta _g$
for all g in G. Note that
 $V_g^{\omega _0}$
is unitarily equivalent to the restriction of
 $V_g^{\omega }$
to
 ${\mathcal H}_0$
.
The above decomposition enables us to study the fixed-point equation
 $V_g^{\omega }x=x$
, x in
 ${\mathcal H}_\omega $
, at the Hilbert space level. Any scalar multiple of the GNS vector
 $\xi _\omega $
is obviously fixed by
 $V_g^\omega $
for all g in G. We shall refer to multiples of
 $\xi _\omega $
as the trivial fixed vectors of
 $V_g^\omega $
.
Proposition 3.7. The unitary group
 $\{V_g^\omega : g\in G\}$
has non-trivial fixed vectors in
 ${\mathcal H}_\omega $
if and only if for some
 $n\neq 0$
the cocycle
 $(u_g^{(n)})_{g\in G}$
is an
 $L^\infty $
-coboundary.
Proof. All we need to show is that there are non-trivial solutions
 $x\in {\mathcal H}_\omega $
of
 $V_g^\omega x=x$
, for all g in G, if and only if there exists
 $n\neq 0$
such that the equation
 $$ \begin{align} \eta(\theta_{g^{-1}}(x))u_g^{(n)}(x)=\eta(x),\quad \mu_0\mbox{-a.e.},\ g\in G, \end{align} $$
has a non-zero solution
 $\eta $
in
 ${\mathcal H}_{\omega _0}=L^2(X, \mu _0)$
.
A straightforward adaptation of the proof of [Reference Del Vecchio, Fidaleo and Rossi5, 8.5] shows that there exist non-trivial x in
 ${\mathcal H}_\omega $
with
 $V_g^\omega x =x$
, for all g in G, if and only if
 $$ \begin{align} \pi_{\omega_0}(\alpha^{-n}(u_g^{(n)}))V_g^{\omega_0}\eta=\eta,\quad g\in G, \end{align} $$
has non-zero solutions
 $\eta $
in
 ${\mathcal H}_{\omega _0}=L^2(X_0, \mu _0)$
for some
 $n\neq 0$
. But with
 ${\mathfrak A}=C(X_0)$
and
 $\omega _0$
given by
 $\omega _0(f)=\int _{X_0} f\,d\mu _0$
, f in
 $C(X_0)$
, equation (3.4) reads
 $$ \begin{align} u_g^{(n)}(\alpha^{n}(x))\eta(\theta_{g^{-1}}(x))=\eta(x),\quad \mu_0\mbox{-a.e.},\ \textrm{for all } g\,\in G. \end{align} $$
The conclusion is reached by observing that if
 $\eta $
in
 $L^2(X_0, \mu _0)$
is a non-trivial solution of (3.5), then
 $\eta '(x)=\eta (\alpha ^{-n}(x))$
,
 $\mu _0$
-a.e., satisfies (3.3).
We now give the characterization of unique ergodicity with respect to the fixed-point subalgebra.
Theorem 3.8. A necessary and sufficient condition for
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
to be uniquely ergodic with respect to the fixed-point subalgebra is that for every n in
 ${\mathbb Z}$
the
 $1$
-cocycle
 $(u_g^{(n)})_{g\in G}$
is not a non-continuous
 $L^\infty $
-coboundary.
Proof. We start by proving that the condition is necessary. We suppose that
 ${({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)}$
is uniquely ergodic with respect to the fixed-point subalgebra and show, for every n in
 ${\mathbb Z}$
, that if the
 $1$
-cocycle
 $(u_g^{(n)})_{g\in G}$
is a coboundary, then it is a continuous coboundary. Suppose there exists some n in
 ${\mathbb Z}$
such that
 $(u_g^{(n)})_{g\in G}$
is a
 $L^\infty $
-coboundary. Then there exists
 $\eta $
in
 $L^\infty (X_0, \mu _0)$
(thought of as
 $\pi _{\omega }(C(X_0))"$
acting on
 ${\mathcal H}_\omega $
) such that
 $\eta \pi _\omega (V^n)\xi _\omega $
is in
 ${\mathcal H}_\omega ^G$
. Now if a is any element of
 ${\mathfrak A}$
, by Proposition 2.2 the sequence
 $\{M_k(aV^n): k\in {\mathbb N}\}$
converges in norm to an element of the form
 $bV^n$
, for some b in
 ${\mathfrak A}$
, which is
 $\Phi ^u$
-invariant by construction. But then
 $\pi _\omega (bV^n)\xi _\omega $
lies in
 ${\mathcal H}_\omega ^G$
, as
 $V_g^\omega \pi _\omega (bV^n)\xi _\omega =\pi _\omega (\Phi _g^u(bV^n))\xi _\omega =\pi _\omega (bV^n)\xi _\omega $
for all g in G. Now the uniqueness up to a multiplicative scalar of the solutions to the cohomological equations at a fixed level implies
 $\eta =\unicode{x3bb} \pi _\omega (b)$
, that is,
 $\eta $
is a continuous solution. Furthermore, b is different from
 $0$
as soon as a is chosen such that
 $\omega _0(aw_n^{*})\neq 0$
.
We next prove that the condition is sufficient as well. This task will be accomplished by showing that every
 $\Phi ^u$
-invariant state
 $\varphi $
on
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
is completely determined by its restriction to
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z})^G$
, under the assumption that for every n in
 ${\mathbb Z}$
the
 $1$
-cocycle
 $(u_g^{(n)})_{g\in G}$
is not a non-continuous
 $L^\infty $
-coboundary.
Let
 $m_0$
be the minimum of the strictly positive integers n such that there exists a non-null
 $a\in {\mathfrak A}$
such that
 $\alpha ^{-m_0}(u_g^{m_0})\theta (a)=a$
, for all g in G.
The first thing we do is to compute the value of
 $\varphi $
on a monomial of the type
 $aV^{km_0}$
. To this end, we first note that
 $$ \begin{align*} &\lim_n M_n(aV^{km_0})=\lim_n M_n (aw_{km_0}^{*}w_{km_0}V^{km_0})\\ &\quad =\lim_n\ M_n(aw_{km_0}^{*})w_{km_0}V^{km_0} = \omega_0(aw_{km_0}^{*})w_{km_0}V^{km_0}. \end{align*} $$
At this point
 $\varphi (aV^{km_0})$
can be easily computed as follows:
 $$ \begin{align*} \varphi(aV^{km_0})&=\varphi(aw_{km_0}^{*}w_{km_0}V^{km_0})=\lim_n\varphi (M_n(aw_{km_0}^{*}w_{km_0}V^{km_0}))\\ &=\omega_0(aw_{km_0}^{*})\varphi(w_{km_0}V^{km_0}), \end{align*} $$
which shows that
 $\varphi (aV^{km_0})$
only depends on the restriction of
 $\varphi $
to
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z})^G$
.
We next show that if l is not a multiple of
 $m_0$
, then
 $\varphi (aV^l)=0$
for all
 $a\in {\mathfrak A}$
. We shall argue by contradiction. Suppose there do exist a in
 ${\mathfrak A}$
and l in
 ${\mathbb Z}\setminus m_0{\mathbb Z}$
such that
 $\varphi (aV^l)\neq 0$
. We will exhibit a non-trivial solution of the cohomological equation right at the level l. To this end, for all g in G and l in
 ${\mathbb Z}$
, we set
 $h_{g, l}:=\Phi _g^u(V^l)V^{-l}$
. Note that
 $h_{g, l}$
sits in
 ${\mathfrak A}$
.
We start with the preliminary limit equality
 $$ \begin{align*} &\lim_n\pi_\varphi(M_n(aV^l))\xi_\varphi=\lim_n\frac{1}{|F_n|}\int_{F_n} V_g^\varphi \pi_\varphi(aV^l) V_g^\varphi \xi_\varphi\,d\mu_G(g)\\ &\quad =\lim_n\frac{1}{|F_n|}\int_{F_n} V_g^\varphi \pi_\varphi(aV^l)\xi_\varphi\,d\mu_G(g)= E_\varphi\pi_\varphi(aV^l)\xi_\varphi, \end{align*} $$
which holds in
 ${\mathcal H}_\varphi $
, with
 $E_\varphi $
being the orthogonal projection onto
 ${\mathcal H}_\varphi ^G\hspace{-1pt}=\hspace{-1pt}\{\xi\hspace{-1pt} \in\hspace{-1pt} {\mathcal H}_\varphi\hspace{-1pt} :\hspace{-1pt} V_g^\varphi \xi\hspace{-1pt} =\hspace{-1pt}\xi , \textrm {for all}\, g\in G\}$
thanks to Proposition 2.4.
We will show that
 $\pi _\varphi (V^{-l})E_\varphi \pi _\varphi (aV^l)\xi _\varphi $
provides the desired solution. This can be seen as follows:
 $$ \begin{align*} &\pi_\varphi(V^{-l})E_\varphi\pi_\varphi(aV^l)\xi_\varphi=\lim_n\pi_\varphi(V^{-l}M_n(aV^l))\xi_\varphi\\ &\quad =\lim_n\frac{1}{|F_n|}\int_{F_n}\pi_\varphi(V^{-l}\theta_g(a) h_{g, l} V^l)\xi_\varphi\,d\mu_G(g)\\ &\quad =\lim_n\frac{1}{|F_n|}\int_{F_n}\pi_\varphi(\alpha^{-l}(\theta_g(a) h_{g, l}))\xi_\varphi\,d\mu_G(g)\\ &\quad =\lim_n\frac{1}{|F_n|}\int_{F_n}\pi_{\omega_0}(\alpha^{.-l}(\theta_g(a) h_{g, l}))\xi_{\omega_0}\,d\mu_G(g), \end{align*} $$
which shows that
 $\pi _\varphi (V^{-l})E_\varphi \pi _\varphi (aV^l)\xi _\varphi $
is in
 ${\mathcal H}_{\omega _0}$
. Moreover,
 $$ \begin{align*} &\pi_{\omega_0}(\alpha^{-l}(u_g^{(l)}))V_{g}^{\omega_0}\pi_\varphi(V^{-l})E_\varphi\pi_\varphi(aV^l)\xi_\varphi\, \\ &\quad =\pi_{\varphi}(\alpha^{-l}(u_g^{(l)}))V_g^\varphi \pi_\varphi(V^{-l})E_\varphi\pi_\varphi(aV^l)\xi_\varphi\\ &\quad =\pi_{\varphi}(\alpha^{-l}(u_g^{(l)})\alpha^{-l}((u_g^{(l)})^{*})V^{-l})E_\varphi\pi_\varphi(aV^l)\xi_\varphi\\ &\quad =\pi_{\varphi}(V^{-l})E_\varphi\pi_\varphi(a V^l)\xi_\varphi, \end{align*} $$
which shows that
 $\pi _\varphi (V^{-l})E_\varphi \pi _\varphi (aV^l)\xi _\varphi $
is indeed a solution. It only remains to show that
 $\pi _\varphi (V^{-l})E_\varphi \pi _\varphi (aV^l)\xi _\varphi \neq 0$
, but this follows directly from
 $$ \begin{align*} \varphi(aV^l)=\langle\xi_\varphi,E_\varphi\pi_\varphi(aV^l) \xi_\varphi\rangle, \end{align*} $$
which in turn follows by the invariance of
 $\varphi $
.
From the proof of the foregoing result, we see at once that unique ergodicity can be characterized by the condition that the cohomological equations for
 $n\geq 1$
do not have non-trivial solutions at all. In such a situation we will say that for every n in
 ${\mathbb Z}\setminus \{0\}$
the
 $1$
-cocycle
 $(u_g^{(n)})_{g\in G}$
is not a coboundary.
Corollary 3.9. A necessary and sufficient condition for
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
to be uniquely ergodic, with unique G-invariant state
 $\omega $
, is that for every n in
 ${\mathbb Z}\setminus \{0\}$
the
 $1$
-cocycle
 $(u_g^{(n)})_{g\in G}$
is not a coboundary.
3.3 Invariant states and invariant conditional expectations
This section provides the complete description of the compact convex set of all invariant states of a skew-product system. We will be working under the tacit assumption that the cohomological equations have non-trivial solutions, otherwise in the light of Corollary 3.9 the system will be uniquely ergodic and there is not much to say about the structure of the set of invariant states. Accordingly,
 $n_0$
will denote the smallest natural number for which the cohomological equations (3.3) have a non-trivial solution, which we denote by
 $w_{n_0}$
. Explicitly,
 $w_{n_0}$
is a function in
 $L^\infty (X_0, \mu _0)$
satisfying
 $\theta _g(w_{n_0})u_g^{(n_0)}=w_{n_0}$
for all g in G, the equality being understood in
 $L^\infty (X_0, \mu _0)$
. Henceforth the solutions
 $w_{kn_0}$
at higher levels, which are unique up to a phase, are chosen in such a way that
 $(w_{n_0}V^{n_0})^k=w_{kn_0}V^{kn_0}$
holds for all k in
 ${\mathbb Z}$
.
The proof of the main result of the section requires some preliminary work. We therefore start by recalling how some natural conditional expectations, which we will need to make use of, can be defined on a crossed product. We denote by
 $\beta _{n_0}$
the automorphism of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
acting on the generators as
 $\beta _{n_0}(a)=a$
, for all a in
 ${\mathfrak A}$
,
 $\beta _{n_0}(V)=e^{{2\pi i}/{n_0}}V$
. We then define
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z})^{\beta _{n_0}}:=\{x\in {\mathfrak A}\rtimes _\alpha {\mathbb Z}\colon \beta _{n_0}(x)=x\}$
. Note that
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z})^{\beta _{n_0}}$
is the
 $C^{*}$
-subalgebra of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
generated by
 ${\mathfrak A}$
and
 $V^{n_0}$
.
We denote by
 $\mathcal {E}_{n_0}$
the canonical conditional expectation of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
onto
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z})^{\beta _{n_0}}$
, that is,
 $\mathcal {E}_{n_0}= ({1}/{n_0})\sum _{k=0}^{n_0-1} \beta _{n_0}^k$
.
Our next goal is to define a map
 $\widetilde {T}\colon ({\mathfrak A}\rtimes _\alpha {\mathbb Z})^{\beta _{n_0}}\rightarrow \pi _\omega (({\mathfrak A}\rtimes _\alpha {\mathbb Z})^{\beta _{n_0}})"$
that acts trivially on
 ${\mathfrak A}$
and sends
 $V^{n_0}$
to
 $w_{n_0}^{*}V^{n_0}$
. Note that this map is well defined, that is, it extends to a
 $*$
-homomorphism defined on the whole of
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z})^{\beta _{n_0}}$
thanks to the universal property of the cross product, for the adjoint action of
 $w_{n_0}^{*}V^{n_0}$
on
 ${\mathfrak A}$
is still
 $\alpha $
due to
 ${\mathfrak A}$
being commutative.
Lastly, we would like to define an expectation
 $\Phi :\pi _\omega (({\mathfrak A}\rtimes _\alpha {\mathbb Z})^{\beta _{n_0}})"\rightarrow L^\infty ({\mathbb T}, m)$
given by
 $\Phi (aV^{ln_0})=\omega _0(a)V^{ln_0}$
, for a in
 ${\mathfrak A}$
and l in
 ${\mathbb Z}$
. This is seen to extend to the whole of
 $\pi _\omega (({\mathfrak A}\rtimes _\alpha {\mathbb Z})^{\beta _{n_0}})"$
by
 $\omega $
-invariance (which means
 $\Phi $
is spatially implemented by an isometry of
 ${\mathcal H}_\omega $
). By composing the three maps above we get a map T defined on
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
by
 $$ \begin{align} T:=\Phi\circ\widetilde{T}\circ\mathcal{E}_{n_0}. \end{align} $$
Note that
 $$ \begin{align} T(aV^{kn_0})=\widetilde{\omega}_0(aw_{kn_0}^{*})V^{kn_0}\quad \textrm{for all } a\, \mathrm{in}\, {\mathfrak A},\ k\, \mathrm{in}\, {\mathbb Z}, \end{align} $$
as follows from
 $(w_{n_0}V^{n_0})^k=w_{kn_0}V^{kn_0}$
for all k in
 ${\mathbb Z}$
.
The map T is invariant under the dynamics and its range is so large as to contain all the powers of
 $V^{n_0}$
.
Lemma 3.10. The unital completely positive map T defined by (3.6) is invariant under
 $\Phi ^u_g$
for all g in G. Moreover, its range contains
 $\mathrm {span}\{V^{kn_0}\colon k\in {\mathbb Z}\}$
.
Proof. In order to prove the equality
 $T\circ \Phi ^u_g=T$
, g in G, it is enough to check that it holds on monomials of the type
 $aV^l$
, a in
 ${\mathfrak A}$
and l in
 ${\mathbb Z}$
. There are two cases depending on whether l is or is not a multiple of
 $n_0$
. If l is not a multiple of
 $n_0$
, then the two sides of the equality certainly agree, both being zero. If
 $l=kn_0$
is a multiple of
 $n_0$
, then the right-hand side is
 $T(aV^{kn_0})=\widetilde {\omega }_0(aw_{kn_0}^{*})V^{kn_0}$
. As for the left-hand side, we have
 $$ \begin{align*} T\circ\Phi^u_g(aV^{kn_0})&=T\circ\Phi^u_g(aw_{kn_0}^{*}w_{kn_0}V^{kn_0})= T(\widetilde{\theta}_g(aw_{kn_0}^{*})w_{kn_0}V^{kn_0})\\ &=\widetilde{\omega}_0(\widetilde{\theta}_g(aw_{kn_0}^{*}))V^{kn_0}=\widetilde{\omega}_0(aw_{kn_0}^{*})V^{kn_0}, \end{align*} $$
thanks to the equality
 $(w_{n_0}V^{n_0})^k=w_{kn_0}V^{kn_0}$
, which holds for all k in
 ${\mathbb Z}$
.
As for the second part of the statement, set
 ${\mathfrak A}=C(X_0)$
. We claim that for every k in
 ${\mathbb Z}$
there exists h (which may depend on k) in
 $C(X_0)$
with
 $\widetilde {\omega }_0(w_{kn_0}^{*}h)=\int \overline {w_{kn_0}}h\,d\mu _0 \neq 0$
(
 $\mu _0$
is the probability measure on
 $X_0$
associated with the state
 $\omega _0$
). Since
 $T(hV^{kn_0})=\widetilde {\omega }_0(w_{kn_0}^{*}h)V^{kn_0}$
and
 $\widetilde {\omega }_0(w_{kn_0}^{*}h)$
is different from
 $0$
, we see that
 $V^{kn_0}$
sits in the range of T.
All that remains is to prove the initial claim. To this end, consider a uniformly bounded sequence
 $\{h_l\colon l\in {\mathbb N}\}\subset C(X_0)$
such that
 $h_l$
converges to
 $w_{kn_0}$
almost everywhere with respect to
 $\mu _0$
. By Lebesgue’s dominated convergence theorem we have
 $\lim _{l\rightarrow \infty } \int \overline {w_{kn_0}}h_l\,d\mu _0 =1$
, which shows that for l large enough
 $h_l$
will work as our h.
In what follows
 $\overline {\mathrm {span}}\{V^{kn_0}\colon k\in {\mathbb Z}\}$
is identified with
 $C({\mathbb T})$
through the
 $*$
-automorphism that sends the generator
 $V^{n_0}$
to the generator of
 $C({\mathbb T})$
, that is, the identical function
 $f(z)=z$
, z in
 ${\mathbb T}$
. This allows us to associate with any Borel probability measure
 $\mu $
on
 ${\mathbb T}$
a state
 $\varphi _\mu $
on
 $\overline {\mathrm {span}}\{V^{kn_0}\colon k\in {\mathbb Z}\}=C^{*}(V^{n_0})$
, defined as
 $\varphi _\mu (V^{kn_0}):=\int _{\mathbb T} z^k\,d{\mu }(z)$
, k in
 ${\mathbb Z}$
.
In order to arrive at the desired characterization of the set of all invariant states, we also need a technical result which basically says that the GNS representation of any invariant state contains a homomorphic image of the whole of the von Neumann algebra
 $L^\infty (X_0, \mu _0)$
. More precisely, we have the following lemma.
Lemma 3.11. For any invariant state
 $\varphi $
in
 ${\mathcal S}({\mathfrak A}\rtimes _\alpha {\mathbb Z})^G$
, the GNS representation
 $\pi _\varphi $
restricted to
 $\pi _{\omega _0}({\mathfrak A})$
extends to a normal representation
 $\widetilde {\pi }_\varphi $
of
 $\pi _{\omega _0}({\mathfrak A})"\cong L^\infty (X_0, \mu _0)$
.
Proof. Let X be an operator belonging to the von Neumann algebra
 $\pi _{\omega _0}({\mathfrak A})"$
. Our next goal is to define a bounded operator
 $\widetilde {\pi }_\varphi (X)$
acting on
 ${\mathcal H}_\varphi $
. We start by defining it on the dense subspace corresponding to the cyclic vector
 $\xi _\varphi $
as follows:
 $$ \begin{align} \widetilde{\pi}_\varphi(X) \pi_\varphi \bigg(\sum_{k\in F} V^k b_k\bigg) \xi_\varphi=\pi_\varphi \bigg(\sum_{k\in F} V^k\alpha^{-k}(X)b_k\bigg) \xi_{\omega_0}, \end{align} $$
where
 $F\subset {\mathbb Z}$
is a finite set of indices and
 $b_k$
an element of
 ${\mathfrak A}$
for all k in F.
In order to verify that (3.8) yields a well-defined bounded operator on
 $\pi _\varphi ({\mathfrak A}\rtimes _\alpha {\mathbb Z})\xi _\varphi $
, we next show that the inequality
 $$ \begin{align*} \bigg\|\pi_\varphi \bigg(\sum_{k\in F} V^k\alpha^{-k}(X)b_k\bigg)\xi_{\omega_0}\bigg\|^2\leq \|X\|^2\bigg\|\pi_\varphi \bigg(\sum_{k\in F} V^k b_k\bigg)\xi_\varphi\bigg\|^2\end{align*} $$
holds. This can be seen by taking a net
 $\{X_\beta : \beta \in I\}$
(say,
 $X_\beta =\pi _{\omega _0}(a_\beta )$
for some net
 $\{a_\beta : \beta \in I\}$
in
 ${\mathfrak A}$
) with
 $\|X_\beta \|\leq \|X\|$
for all
 $\beta $
in I:
 $$ \begin{align*} &\bigg\|\pi_\varphi \bigg(\sum_{k\in F} V^k\alpha^{-k}(X)b_k\bigg) \xi_{\omega_0}\bigg\|^2=\lim_\beta\bigg\|\pi_\varphi \bigg(\sum_{k\in F} V^k\alpha^{-k}(X_\beta)b_k\bigg) \xi_{\omega_0}\bigg\|^2\\ &\quad =\lim_\beta\bigg\|\pi_\varphi \bigg(\sum_{k\in F} V^k\alpha^{-k}(\pi_{\omega_0}(a_\beta))b_k\bigg) \xi_{\omega_0}\bigg\|^2= \lim_\beta \bigg\| \pi_{\varphi}(a_\beta)\pi_\varphi \bigg(\sum_{k\in F}V^kb_k\bigg) \xi_\varphi\bigg\|^2\\ &\quad \leq\|X\|^2 \bigg\|\pi_\varphi \bigg(\sum_{k\in F}V^kb_k\bigg) \xi_\varphi\bigg\|^2. \end{align*} $$
All that remains is to show that
 $\widetilde {\pi }_\varphi $
is a representation. Now from its definition it is obvious that the restriction of
 $\widetilde {\pi }_\varphi $
to
 $\pi _{\omega _0}({\mathfrak A})$
is
 $*$
-preserving and multiplicative. The full conclusion will be reached by strong density of
 $\pi _{\omega _0}({\mathfrak A})$
in its bicommutant if we prove that
 $\widetilde {\pi }_\varphi $
is a strongly continuous map. Now, as a straightforward consequence of (3.8) we see that
 $\widetilde {\pi }_\varphi $
is strongly continuous on the unit ball of
 $\pi _{\omega _0}({\mathfrak A})"$
. Thus by the Kaplansky density theorem the map
 $\widetilde {\pi }_\varphi $
is strongly continuous on the whole of
 $\pi _{\omega _0}({\mathfrak A})"$
.
Remark 3.12. For any operator X sitting in the von Neumann algebra
 $\pi _{\omega _0}({\mathfrak A})"$
one has
 $$ \begin{align*} \widetilde{\pi}_\varphi (V_g^{\omega_0}X(V_g^{\omega_0})^{*})= V_g^\varphi\widetilde{\pi}_\varphi(X)(V_g^\varphi)^{*}.\end{align*} $$
The above equality follows from
 $\widetilde {\pi }_\varphi (\pi _{\omega _0}(a))=\pi _\varphi (a)$
, a in
 ${\mathfrak A}$
. Indeed, one has
 $\widetilde {\pi }_\varphi (V_g^{\omega _0}\pi _{\omega _0}(a)(V_g^{\omega _0})^{*})=\widetilde {\pi }_\varphi (\pi _{\omega _0}(\theta _g(a)))=\pi _{\varphi }(\theta _g(a))=V_g^\varphi \pi _\varphi (a) {V_g^{\varphi }}^{*}$
for all a in
 ${\mathfrak A}$
, whence the conclusion by normality of
 $\widetilde {\pi }_\varphi $
.
We are finally in a position to provide the structure of the set of all invariant states.
Theorem 3.13. If a skew product
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u )$
is not uniquely ergodic, then the map
 $\Psi \colon {\mathcal P}({\mathbb T})\rightarrow {\mathcal S}({\mathfrak A}\rtimes _\alpha {\mathbb Z})^G$
given by
 $$ \begin{align*} \Psi(\mu):=\varphi_\mu\circ T,\quad \mu\in {\mathcal P}({\mathbb T})\end{align*} $$
is an affine homeomorphism between compact convex sets.
Proof. Under the assumption that the system is not uniquely ergodic, the smallest natural number,
 $n_0$
, corresponding to which there is a non-trivial solution of the cohomological equation is well defined, as is the map T in Lemma 3.10.
The map
 $\Psi $
is clearly affine. We next show that it is a bijection. To this end, we first note that
 $\Psi $
is injective, as follows from the density of the range of T in
 $C({\mathbb T})$
established in Lemma 3.10. Proving its surjectivity is a far more demanding task. Let
 $\eta $
be a G-invariant state on
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
. In order to exhibit the state
 $\varphi _\mu $
on
 $C^{*}(V^{n_0})$
our state
 $\eta $
comes from, we need to consider a representation
 $\rho _\eta $
of
 $C({\mathbb T})$
acting on the Hilbert space
 ${\mathcal H}_\eta $
which is defined as
 $$ \begin{align*} \rho_\eta(z^l):= \widetilde{\pi}_\eta (w_{ln_0})\pi_\eta(V^{ln_0}),\quad l\in{\mathbb Z}. \end{align*} $$
Let
 $\mu $
be the spectral measure of the above representation associated with
 $\xi _\eta $
, namely the Borel probability measure uniquely determined by
 $\int _{\mathbb T} f\,d\mu =\langle \rho _\eta (f)\xi _\eta , \xi _\eta \rangle $
, for all f in
 $C({\mathbb T})$
. We claim that
 $\mu $
is precisely the desired measure, namely that
 $\varphi _\mu \circ T=\eta $
. To show this, it is enough to make sure that
 $\varphi _\mu (T(aV^k))=\eta (aV^k)$
holds for all a in
 ${\mathfrak A}$
and k in
 ${\mathbb Z}$
. There are two cases. Suppose k is not a multiple of
 $n_0$
. In this case,
 $\eta (aV^k)=0$
, as we saw over the course of the proof of Theorem 3.8, and
 $T(aV^k)=0$
too, which we saw at the beginning of the proof of Lemma 3.10.
If now k is a multiple of
 $n_0$
(say,
 $k=ln_0$
), we have
 $$ \begin{align*} \varphi_\mu(T(aV^{ln_0}))=\widetilde{\omega}_0(aw_{ln_0}^{*})\varphi_\mu(V^{ln_0}). \end{align*} $$
On the other hand, we can compute
 $\eta (aV^{ln_0})$
as follows:
 $$ \begin{align*} &\eta(aV^{ln_0})=\langle \pi_\eta(aV^{ln_0})\xi_\eta, \xi_\eta \rangle= \langle\pi_\eta(a)\widetilde{\pi}_\eta(w_{ln_0}^{*})\widetilde{\pi}_\eta(w_{ln_0})\pi_\eta(V^{ln_0})\xi_\eta, \xi_\eta \rangle\\ &\quad =\frac{1}{\mu_G(F_n)}\int_{F_n}\langle V_g^\eta\pi_\eta(a)\widetilde{\pi}_\eta(w_{ln_0}^{*})(V_g^\eta)^{*} V_g^\eta \widetilde{\pi}_\eta(w_{ln_0})\pi_\eta(V^{ln_0})\xi_\eta, \xi_\eta \rangle\,\mu_G(g). \end{align*} $$
Now
 $({1}/{\mu _G(F_n)})\int _{F_n} V_g^\eta \pi _\eta (a)\widetilde {\pi }_\eta (w_{ln_0}^{*})(V_g^\eta )^{*}\,d\mu _G(g)$
converges as a sequence in
 $L^\infty (X_0, \mu _0)$
to
 $\widetilde {\omega }_0(aw_{ln_0}^{*}) \mu _0$
-a.e. thanks to Lindenstrauss’s pointwise ergodic theorem ([Reference Lindenstrauss9, Theorem 1.2]), which applies because every Følner sequence has a tempered subsequence (again see [Reference Lindenstrauss9]).
We claim that
 $\widetilde {\pi }_\eta (w_{ln_0})\pi _\eta (V^{ln_0})\xi _\eta $
is
 $V_g^\eta $
-invariant, which means that
 $$ \begin{align*} V_g^\eta \widetilde{\pi}_\eta(w_{ln_0})\pi_\eta(V^{ln_0})\xi_\eta=\widetilde{\pi}_\eta(w_{ln_0})\pi_\eta(V^{ln_0})\xi_\eta,\quad g\in G. \end{align*} $$
But then
 $$ \begin{align*} &\lim_{n\rightarrow\infty}\frac{1}{\mu_G(F_n)}\int_{F_n} \langle V_g^\eta\pi_\eta(a)\widetilde{\pi}_\eta(w_{ln_0}^{*})(V_g^\eta)^{*} V_g^\eta\widetilde{\pi}_\eta(w_{ln_0})\pi_\eta(V^{ln_0})\xi_\eta, \xi_\eta \rangle\,d{\mu_G}(g)\\ &\quad =\widetilde{\omega}_0(aw_{ln_0}^{*})\langle \widetilde{\pi}_\eta(w_{ln_0})\pi_\eta(V^{ln_0})\xi_\eta, \xi_\eta \rangle= \widetilde{\omega}_0(aw_{ln_0}^{*})\langle \rho_\eta(z^l)\xi_\eta, \xi_\eta \rangle \\ &\quad = \widetilde{\omega}_0(aw_{ln_0}^{*})\varphi_\mu(V^{ln_0}). \end{align*} $$
To conclude, we prove the claim. To this end, we start from the equation satisfied by
 $w_{ln_0}$
written in the form
 $V_g^{\omega _0}w_{ln_0}(V_g^{\omega _0})^{*}\pi _{\omega _0}(u_g^{(ln_0)})=w_{ln_0}$
. Taking
 $\widetilde {\pi }_\eta $
on both sides of the equation and taking into account Remark 3.12, we find
 $V_g^\eta \widetilde {\pi }_\eta (w_{ln_0})(V_g^\eta )^{*} \pi _\eta (u_g^{(ln_0)})=\widetilde {\pi }_\eta (w_{ln_0})$
. But then we have
 $$ \begin{align*} &V_g^\eta\widetilde{\pi}_\eta(w_{ln_0})\pi_\eta(V^{ln_0})\xi_\eta=V_g^\eta\widetilde{\pi}_\eta(w_{ln_0})(V_g^\eta)^{*}V_g^\eta\pi_\eta(V^{ln_0})\xi_\eta\\ &\quad =\widetilde{\pi}_\eta(w_{ln_0})\pi_\eta((u_g^{ln_0})^{*})V_g^\eta\pi_\eta(V^{ln_0})(V_g^\eta)^{*}\xi_\eta\\ &\quad =\widetilde{\pi}_\eta(w_{ln_0})\pi_\eta((u_g^{ln_0})^{*})\pi_\eta(u_g^{ln_0}V^{ln_0})\xi_\eta\\ &\quad =\widetilde{\pi}_\eta(w_{ln_0})\pi_\eta(V^{ln_0})\xi_\eta, \end{align*} $$
and the proof is now complete.
We conclude this section with a result which, among other things, proves that Abadie and Dykema’s problem can be answered in the affirmative in the class of skew products.
Theorem 3.14. Let
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
be a skew-product system, with
 $({\mathfrak A}, G, \theta )$
being a uniquely ergodic system with unique invariant state
 $\omega _0$
. The following conditions are equivalent.
-
(i)
$({\mathfrak A}\rtimes _\alpha {\mathbb Z}, G, \Phi ^u)$
is uniquely ergodic with respect to the fixed-point subalgebra
$({\mathfrak A}\rtimes _\alpha {\mathbb Z})^G$
. -
(ii) There exists a unique G-invariant conditional expectation from
${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
onto
$({\mathfrak A}\rtimes _\alpha {\mathbb Z})^G$
. -
(iii) For every n in
${\mathbb N}$
, if the cocycle
$(u_g^{(n)})_{g\in G}$
is a coboundary, then it is a continuous coboundary.


Proof. The implication (i)
 $\,\Rightarrow \,$
(ii) holds in general. As for the implication (ii)
 $\,\Rightarrow \,$
(iii), suppose that (iii) does not hold. Then the cohomological equations also have non-continuous solutions. We denote by
 $n_0$
the smallest natural number for which there is a (non-continuous) solution and by
 $m_0$
the smallest natural number for which the solution is continuous. We have
 $m_0=kn_0$
for some (possibly infinite)
 $k>0$
. Following [Reference Del Vecchio, Fidaleo and Rossi6], we next show that under the current hypotheses we can exhibit many different
 $\Phi ^u$
-invariant conditional expectations. To this end, we continue to identify
 $C^{*}(V^{n_0})$
with
 $C({\mathbb T})$
. With this identification, we may think of the map T in Lemma 3.10 as taking values in
 $C({\mathbb T})$
, that is,
 $T(aV^{ln_0})=\widetilde {\omega }_0(aw_{ln_0}^{*})z^l$
. As recalled towards the end of page
 $13$
of [Reference Del Vecchio, Fidaleo and Rossi6], there are many different conditional expectations from
 $C({\mathbb T})$
onto its subalgebra
 $C^{*}(\chi _k)$
generated by the character
 $\chi _k(z)=z^k$
, z in
 ${\mathbb T}$
. Denote by F any such conditional expectation.
Now
 $C^{*}(\chi _k)\hspace{-0.3pt}\cong\hspace{-0.3pt} C^{*}(w_{kn_0}V^{kn_0})\hspace{-0.5pt}=\hspace{-0.5pt}({\mathfrak A}\hspace{-0.5pt}\rtimes _\alpha\hspace{-0.5pt} {\mathbb Z})^G$
through the
 $*$
-isomorphism
 $\Psi \colon\hspace{-0.3pt} C^{*}(\chi _k)\rightarrow C^{*}(w_{kn_0}V^{kn_0})$
such that
 $\Psi (\chi _k):=w_{kn_0}V^{kn_0}$
.
By construction, the composition
 $E_F=\Psi \circ F\circ T$
provides a G-invariant conditional expectation onto
 $({\mathfrak A}\rtimes _\alpha {\mathbb Z})^G$
and we are done because this procedure yields many different conditional expectations, as explained at length in [Reference Del Vecchio, Fidaleo and Rossi6, Proposition 3.10].
Acknowledgements
We would like to thank Dan Ursu for allowing us to include in the present paper his solution (Example 2.1) to the problem posed by Abadie and Dykema, which he let us have in a private communication. Special thanks are also due to the anonymous referees, whose many valuable comments have improved the paper’s readability. Finally, the authors acknowledge INdAM-GNAMPA Project 2024 ‘Probabilità quantistica e applicazioni’. V. C., S. D. V. and S. R. are also supported by Italian PNRR Partenariato Esteso PE4, NQSTI, and Centro Nazionale CN00000013 CUP H93C22000450007. M.E.G. is supported by Italian PNRR MUR project PE0000023-NQSTI, CUP H93C22000670006, and Progetto ERC SEEDS UNIBA ‘
 $C^{*}$
-algebras and von Neumann algebras in Quantum Probability’, CUP H93C23000710001.
A Appendix
We collect here some possibly known results which are needed to give a self-contained proof of Lemmas A.5 and A.6, which in turn are among the key tools required to prove Theorem 3.3.
Lemma A.1. Let
 $X_0$
be a compact Hausdorff space with infinitely many points and let
 $\alpha $
be a minimal homeomorphism of
 $X_0$
. If
 $g\in C(X_0)$
satisfies
 $(f\circ \alpha ^n) g=fg$
for all f in
 $C(X_0)$
and for all
 $n\neq 0$
, then
 $g=0$
.
Proof. We shall argue by contradiction. Let n be a fixed non-zero integer. Suppose there exists
 $x_0$
in
 $X_0$
with
 $g(x_0)\neq 0$
. Then simplifying the given equality by
 $g(x_0)$
, we find
 $f(\alpha ^n(x_0))=f(x_0)$
. Under our hypotheses, we can assume
 $\alpha ^n(x_0)\neq x_0$
, for otherwise
 $\{\alpha ^k(x_0)\colon k\in {\mathbb N}\}$
would be a proper closed subset invariant under
 $\alpha $
. The contradiction is now reached by considering a continuous function f that separates
 $x_0$
and
 $\alpha ^n(x_0)$
.
Remark A.2. As a straightforward application of the above result, we also find the following result. Under the same hypotheses as Lemma A.1, let
 $\mu _0$
be a faithful
 $\alpha $
-invariant probability measure on
 $X_0$
. If g in
 $L^\infty (X_0,\mu _0)$
satisfies
 $f(\alpha ^n(x))g(x)=f(x)g(x) \mu _0$
-a.e. for all f in
 $L^\infty (X_0,\mu _0)$
for some
 $n\neq 0$
, then g is zero
 $\mu _0$
-a.e.
Lemma A.3. If
 ${\mathfrak A}=C(X_0)$
is a commutative
 $C^{*}$
-algebra with infinite spectrum
 $X_0$
and
 $\alpha $
is a minimal homeomorphism of
 $X_0$
, then
 ${\mathfrak A}$
is maximal abelian in
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
.
Proof. We need to show that if x in
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
commutes with any a in
 ${\mathfrak A}$
, then x itself sits in
 ${\mathfrak A}$
. Recall that for any such x the Fourier expansion
 $x=\sum _n V^n E(V^{-n}x)$
holds with respect to the norm topology if the convergence is understood in the Cesàro sense. In terms of the above expansion, the equality
 $xa=ax$
reads
 $\sum _n V^n E(V^{-n}x)a=\sum _n a V^n E(V^{-n}x)$
, that is,
 $$ \begin{align*} \sum_n V^n E(V^{-n}x)a=\sum_n V^n \alpha^{-n}(a) E(V^{-n}x). \end{align*} $$
By uniqueness of the Fourier expansion, we must have
 $\alpha ^{-n}(a) E(V^{-n}x)=E(V^{-n}x)a$
for all a in
 ${\mathfrak A}$
, which implies
 $E(V^{-n}x)=0$
for all
 $n\neq 0$
thanks to Lemma A.1. But then
 $x=E(x)$
and we are done.
Lemma A.4. Let
 $X_0$
be an infinite compact Hausdorff space and
 $\alpha $
a homeomorphism of
 $X_0$
. If
 $(C(X_0), \alpha )$
is a uniquely ergodic system whose unique invariant state
 $\omega _0$
is faithful then
 $\pi _{\omega _0}({\mathfrak A})"$
is maximal abelian in
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
.
Proof. This is an easy adaptation of the proof of Lemma A.3 by taking into account that the Fourier expansion holds at the von Neumann algebra level as well, that is, for any operator T in
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
one has
 $T=\sum _n \pi _\omega (V^n) \widetilde {E}(V^{-n}x)$
(see [Reference Del Vecchio, Fidaleo and Rossi5, Proposition 4.2]), and exploiting Remark A.2.
Lemma A.5. Let
 $\alpha $
be a minimal homeomorphism of an infinite compact Hausdorff space
 $X_0$
. Set
 $ C(X_0):={\mathfrak A}$
. If
 $\Psi $
is an automorphism of
 ${\mathfrak A}\rtimes _\alpha {\mathbb Z}$
with
 $\Psi (a)=a$
for all a in
 ${\mathfrak A}$
, then there exists a unitary w in
 ${\mathfrak A}$
such that
 $\Psi (V)=wV$
.
Proof. We only deal with the
 $C^{*}$
-case, for the
 $W^{*}$
-case can be handled in the same way. From the equality
 $VaV^{*}=\alpha (a)$
,
 $a\in {\mathfrak A}$
, we find
 $\Psi (V)a\Psi (V^{*})=\alpha (a)$
, which means
 $VaV^{*}=\Psi (V)a\Psi (V^{*})$
,
 $V^{*}\Psi (V)a=aV^{*}\Psi (V)$
for all a in
 ${\mathfrak A}$
. The conclusion follows by Lemma A.3, which implies that
 $V^{*}\Psi (V)$
is a unitary w sitting in
 ${\mathfrak A}$
.
Likewise, we have a
 $W^{*}$
version of the above in the light of Remark A.2.
Lemma A.6. Let
 $\alpha $
be a uniquely ergodic homeomorphism of an infinite compact Hausdorff space
 $X_0$
with unique invariant measure
 $\mu _0$
with full support. Set
 $C(X_0):={\mathfrak A}$
. If
 $\Psi $
is an automorphism of
 $\pi _\omega ({\mathfrak A}\rtimes _\alpha {\mathbb Z})"$
with
 $\Psi (\pi _\omega (a))=\pi _\omega (a)$
for all a in
 ${\mathfrak A}$
, then there exists a unitary w in
 $\pi _{\omega _0}({\mathfrak A})"$
such that
 $\Psi (\pi _\omega (V))=w\pi _\omega (V)$
, where
 $\omega $
is the canonical extension to the crossed product of the state
 $\omega _0$
on
 $L^\infty (X_0, \mu _0)$
given by
 $\omega _0(f):=\int _{X_0} f\,d\mu _0$
, f in
 $L^\infty (X_0, \mu _0)$
.



