





Background
Burial in a snow avalanche is a time-sensitive emergency. A critically buried victim is a person whose head and chest are covered, and survival depends primarily on time to extrication, airway patency, presence of an air pocket, burial depth, and associated trauma. The duration of burial is particularly important for survival and is often dependent on ground companion rescue with avalanche transceivers, avalanche probe, and shovel. For victims equipped with such transceivers, companion rescue remains the principal means of localization and extrication. The classical survival curve demonstrates a steep decline after 10-15 minutes.Reference Pasquier, Strapazzon and Kottmann1–Reference Wallner, Woyke and Winkler5 An air pocket in front of the victim’s mouth and nose may permit breathing if the airway is patent. However, vapor from the breathing may freeze in the snow, creating an ice lens that may reduce gas exchange.Reference Procter, Strapazzon and Dal Cappello6 The European Avalanche Warning Services (Innsbruck, Austria) classifies avalanches into five sizes, and a typical skier-triggered avalanche is classified as Size 2 or Size 3, characterized by a slab approximately 50–80m wide, 150m long, and 50cm thick – equivalent to roughly 400 tons of snow.7 Median depth of burial for patients with air pocket is 60cm, while median depth of all buried patients is 100cm.Reference Genswein, Macias, McIntosh, Reiweger, Hetland and Paal8 Burial depth is relevant to survival and the necessary time to both localization and extrication.Reference Procter, Strapazzon and Dal Cappello6,Reference Genswein, Macias, McIntosh, Reiweger, Hetland and Paal8,Reference Ayuso, Cuchí, Lera and Villarroel9
Since 1996, international guidelines for the prevention, rescue, and clinical management of avalanche victims have been established and regularly updated.Reference Brugger, Durrer and Adler-Kastner10–Reference Van Tilburg, Grissom and Zafren12 In Northern Europe, avalanches accounts for more than 100 deaths per year.Reference Kottmann, Carron, Theiler, Albrecht, Tissi and Pasquier13,Reference Techel, Jarry and Kronthaler14 In Norway, 806 individuals were caught in snow avalanches over the last decade, resulting in 127 injuries and 57 deaths.15,16 Most of these incidents were triggered by skiers or recreationalists. In a national retrospective study of Norwegian avalanche incidents from 1996 to 2017, approximately 30% were rescued by companions, 35% self-rescued, while 35% waited for organized rescue.Reference Lunde and Tellefsen17
Both due to the time-critical nature of burial, remote locations, and high frequency of concomitant severe trauma, Helicopter Emergency Medical Services (HEMS) or Search-and-Rescue (SAR) helicopters are often dispatched to these incidents.Reference Kottmann, Carron, Theiler, Albrecht, Tissi and Pasquier13,Reference Strapazzon, Thomassen and Van Tilburg18,19 If ground companion rescue has not yet localized the victim(s), the helicopters may then be a primary asset for localization, especially if the avalanche area is too large or hazardous for ground search or if victims are unaccompanied. In Norway, these missions are often performed by SAR helicopters.19,Reference Reid, Haugland, Rehn, Uleberg and Krüger20 The 330 Squadron in the Norwegian Air Force operates six out of seven SAR helicopter bases on the Norwegian mainland. The squadron currently utilizes two standardized search protocols for localization of victims equipped with transceivers: either the use of an underslung antenna or hoist deployment of a rescue paramedic (RP) with a handheld transceiver. While both methods are integrated into training and operational protocols, there is a lack of formal comparisons to determine their relative efficiency.
The aim of this study was to characterize the timeline of these procedures during a randomized, experimental field trial with repeated trial runs to identify which procedure provides the most efficient strategy to localize a buried avalanche victim.
Methods
Study Setting
Participants consisted of the crew on duty at the SAR helicopter at 330-Squadron, Norwegian Air Force, Ørland Main Airforce Base (Trøndelag, Norway). The 330 Squadron operates the Leonardo AW101 helicopter with a six-person crew: two pilots, a system operator, a flight engineer/hoist operator, a RP, and a consultant anesthesiologist. The RP is the primary rescue resource; however, the physician may also be hoisted in selected cases, similar to other HEMS systems.Reference Reid, Haugland, Rehn, Uleberg and Krüger20–Reference Wilhelm and Lefering23 All crew members were willingly participants, and the study was conducted as a standard training exercise. A risk assessment was performed by the pilot in command prior to the exercise. One crew performed all the trial runs in the study.
Study Area
The study was performed in a decommissioned alpine ski area near the helicopter base. A simulated avalanche area (80m × 150m) was packed by skis and foot traffic with borders marked for visibility (Figure 1). There were large trees outside the borders, while the avalanche area was without terrain modifiers such as trees and large rocks. Six transceivers (EasySearcher 4, Manuel Genswein; Switzerland) were buried at various locations within the avalanche, at a depth of approximately 0.5m. Studies suggest that chance for survival rapidly declines if burial depth is deeper than 50-100cm.Reference Genswein, Macias, McIntosh, Reiweger, Hetland and Paal8 However, the depth was chosen to create reproducible experimental condition for comparing the helicopter search strategy, focusing on the localization performance, and not to represent the full range of clinically encountered burial depths. The precise locations were fixed for all trial runs and known only to the principal investigator (PI) and two ground-based study assistants.
Sketch of a Simulated Avalanche Area, with Six Transceivers Buried.

Figure 1. Long description
A diagram of a simulated avalanche area. The diagram includes a summit, ridge line, forest border, and open slope. The avalanche path is marked with a start zone/release point, a steep slope, and a deposition zone. The avalanche path is 150 meters long and 80 meters wide. Six receiver locations (R1 to R6) are indicated along the avalanche path. The flow direction of the avalanche is shown with arrows. The diagram also includes labels for the track and the avalanche margin.
Study Procedures
The 330 Squadron utilizes two standardized avalanche search procedures, both of which involve use of the helicopter’s electrical rescue hoist (HS-29900-66, Breeze-Eastern; Hanover, New Jersey USA), featuring a maximum workload of 272kg and a maximum wire length of 88m (290 feet). When the RP is lowered to ground, the standard procedure is that the RP will remain connected to the hoist cable if there is a secondary avalanche risk or will unhook if the area is deemed stable to perform fine search and excavation. In this study, the RP unhooked from the hoist cable in all trial runs. Both procedures were performed as they would have been in a real mission. The RP may communicate with the rest of the crew via hands-free radio or use hand signals according to standard flight operational procedures.
Antenna Search Procedure
A Girsberger HAS457-2 antenna (Girsberger Elektronik AG; Flaach, Switzerland) was attached to the hoist hook. The antenna detects signals from the 457 kHz frequency, the international standard radio band for avalanche transceivers, with an omnidirectional antenna. At antenna height of 20m above snow, the specified search-strip width is approximately 80m and is designed to be suspended below the helicopter to reduce electromagnetic interference.24 The hoist hook was lowered three feet and the antenna attached to the hook with a 9.5m long rope. The search was then performed with the antenna suspended approximately nine meters below the helicopter. Helicopter flight altitude was aimed at 100 feet, with the antenna approximately 20m above ground. Upon detecting a signal, the system provided visual and auditory alerts. Once the signal strength was optimized, a crew member dropped a flag at the location. The RP was then hoisted to the ground to conduct a fine search using a handheld transceiver (Barryvox S, Mammut Sport Group; Seon, Aargau, Switzerland), followed by excavation of the transceiver.
Rescue Paramedic in Hoist Procedure
The RP was hoisted to approximately five-to-ten meters above the ground (or at tree-top height) to perform a search using a handheld Barryvox S transceiver (Figure 2) with a receiver range of 70m in standard search mode used.Reference Mammut25 Upon receiving the initial signal (auditory and visual on the transceiver screen), the RP signaled the crew to guide the helicopter’s direction. Once the RP considered the signal to be as optimal as possible, the RP signaled to the crew and was lowered to the ground for a fine search and excavation of the transceiver.
Recue Paramedic in the Hoist of the AW101 Helicopter during a Training Exercise.

Randomization and Data Collection
The search procedure for each trial was randomized by the PI using a web-based tool,26 with the sequence known only to the PI and the crew physician, that registered the data during the study runs. To prevent search bias, only one transceiver was active per run; the activation sequence was randomized using the same web-based tool and managed by the PI and ground assistants.
The crew physician, positioned inside the cabin and connected to the intercom system, recorded four primary timestamps for each run: (1) First Signal: Acknowledged by the crew (Antenna Search) or the RP (RP Hoist Search); (2) Optimal Signal: Point of maximum signal strength; (3) RP on Ground: Moment the RP contacted the surface; and (4) Transceiver Found: When the RP concluded the fine search and decided to begin pinpoint search with a probe or excavation.
Each run commenced with the helicopter in a stable hover 200m from the search area at a flight altitude of approximately 200 feet, comparable to a real mission search strategy. The crew were prepared to start either the Antenna Search or the RP Hoist Search. The physician then told the crew which of the procedures they should perform according to the randomized sequence, and the time started.
Statistical Analysis
An a priori sample size calculation was performed based on an author-anticipated between-strategy difference of five minutes in time to Transceiver Found and an assumed standard deviation of three minutes. With a two-sided α of 0.05 and 80% power, approximately seven trial runs per search strategy were required. Primary endpoint was defined as the total time to Transceiver Found, as this is the most clinical meaningful endpoint for the patient. Other time differences were secondary endpoints. Continuous variables are reported as mean (standard deviation [SD]). The search strategy was randomized for each run. The primary endpoint is analyzed using a Welch’s two-sample t-test. Mean differences are reported with 95% confidence intervals (CI). The widths of the 95% CI for secondary and exploratory outcomes have not been adjusted for multiplicity, and the intervals should not be used in place of hypothesis testing. As all trial runs were performed by the same crew, a potential learning effect was considered. An exploratory sensitivity analysis was performed using the within-strategy run order. A linear regression model for the primary endpoint included the search strategy, run number within the strategy, and a strategy-by-run-number interaction. The run number was centered within each search strategy to allow the main effect of the search strategy to represent the difference between-group at the mean run sequence. Heteroscedasticity-robust (HC3) standard errors were used. The interaction term was used to assess whether the rate of change across following runs differed between the two search strategies. A P < 0.05 (2-tailed) was regarded as statistically significant. Statistical analysis is performed with SPSS Version 25.0 (IBM Corp; Armonk, New York USA).
The manuscript was prepared with reference to relevant CONSORT (CONsolidated Standards Of Reporting Trials) Statement recommendations (Supplementary Material).27
Ethics Approval and Consent to Participate
The study was approved by the Regional Committee for Medical and Health Research Ethics (reference 984897 REK-Midt) and by the flight insurance officer at the 330 Squadron, Royal Norwegian Air Force.
Results
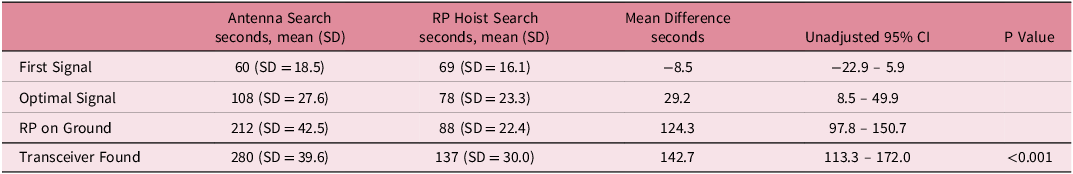
In three days, a total of 25 study runs were performed: 13 with Antenna Search and 12 with RP Hoist Search. All trial runs successfully located the transceiver. The weather (visibility, precipitation, and wind) was identical all three days; trial runs were performed during daytime, good visibility, no precipitation, and with mild/moderate wind conditions. The time from start to Transceiver Found (primary endpoint) was lower in the RP Hoist Search versus Antenna Search, with a difference between the groups of 143 seconds (95% CI, 113 – 172; P <0.001). Figure 3 shows the box-plot comparison between the search strategies. Figure 4 demonstrates the timeline of the different timestamps registered.
Box-Plot Comparison of the Two Search Strategies.

Timeline of Timestamps Registered in the Two Search Strategies.
Abbreviation: RP, rescue paramedic.

Figure 4. Long description
A diagram comparing two search strategies for locating a transceiver using a helicopter. The diagram includes two lines representing the Antenna Search Method and the RP Hoist Search Method. The Antenna Search Method starts at the left with the search start (door open) and progresses through first signal, optimal signal, RP on ground, and receiver found. The RP Hoist Search Method follows a similar path but with different timings. Key points are marked along each line, indicating the stages of the search process. The timeline at the bottom shows the time in seconds from 0 to 300, with specific points marked for each stage of the search process. The diagram illustrates that the RP Hoist Search Method locates the receiver faster than the Antenna Search Method.
The mean times for each operational timestamp are summarized in Table 1. Time to First Signal was 8.5 seconds shorter with the Antenna Search. Thereafter, the RP Hoist Search reached an Optimal Signal, reached ground, and localized the transceiver significantly faster than the Antenna Search.
Times During Two Differing Search Strategies

Table 1. Long description
A table comparing the mean times for different operational timestamps during two search strategies. The table has 4 rows and 5 columns. Column headers are Antenna Search seconds, mean (SD), RP Hoist Search seconds, mean (SD), Mean Difference seconds, Unadjusted 95 percent CI, and P Value. Row labels are First Signal, Optimal Signal, RP on Ground, and Transceiver Found. Row 1: Antenna Search seconds, mean (SD) 60 (SD = 18.5); RP Hoist Search seconds, mean (SD) 69 (SD = 16.1); Mean Difference seconds -8.5; Unadjusted 95 percent CI -22.9 – 5.9; P Value. Row 2: Antenna Search seconds, mean (SD) 108 (SD = 27.6); RP Hoist Search seconds, mean (SD) 78 (SD = 23.3); Mean Difference seconds 29.2; Unadjusted 95 percent CI 8.5 – 49.9. Row 3: Antenna Search seconds, mean (SD) 212 (SD = 42.5); RP Hoist Search seconds, mean (SD) 88 (SD = 22.4); Mean Difference seconds 124.3; Unadjusted 95 percent CI 97.8 – 150.7. Row 4: Antenna Search seconds, mean (SD) 280 (SD = 39.6); RP Hoist Search seconds, mean (SD) 137 (SD = 30.0); Mean Difference seconds 142.7; Unadjusted 95 percent CI 113.3 – 172.0; P Value <0.001.
Note: Mean difference between groups is calculated by Antenna search – RP hoist search. The width of the 95% CI has not been adjusted for multiplicity, and they should not be used in place of hypothesis testing.
Abbreviation: RP, rescue paramedic.
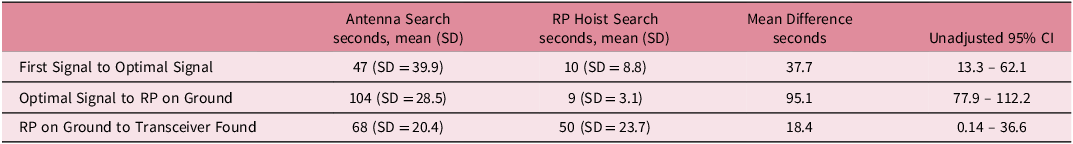
Phase-specific analysis is summarized in Table 2. In the signal acquisition phase (time from First Signal to Optimal Signal), the difference between the groups was 38 seconds (95% CI, 13 – 21). In the deployment phase (time from Optimal Signal to the RP on Ground), the difference between the groups was 95 seconds (95% CI, 78 – 112). After the RP reached the ground, localization of the buried transceiver required significantly less time with RP Hoist Search versus Antenna Search, with a difference between the groups of 18 seconds (95% CI, 0 – 37).
Phase-Specific Analysis

Table 2. Long description
The table compares the search times for two methods, Antenna Search and RP Hoist Search, across different phases. It has four rows and five columns. The columns are labeled as Antenna Search seconds, mean (SD), RP Hoist Search seconds, mean (SD), Mean Difference seconds, and Unadjusted 95% CI. The rows are labeled as First Signal to Optimal Signal, Optimal Signal to RP on Ground, and RP on Ground to Transceiver Found. Row 1: Antenna Search seconds, mean (SD) 47 (39.9); RP Hoist Search seconds, mean (SD) 10 (8.8); Mean Difference seconds 37.7; Unadjusted 95% CI 13.3 – 62.1. Row 2: Antenna Search seconds, mean (SD) 104 (28.5); RP Hoist Search seconds, mean (SD) 9 (3.1); Mean Difference seconds 95.1; Unadjusted 95% CI 77.9 – 112.2. Row 3: Antenna Search seconds, mean (SD) 68 (20.4); RP Hoist Search seconds, mean (SD) 50 (23.7); Mean Difference seconds 18.4; Unadjusted 95% CI 0.14 – 36.6.
Note: The width of the 95% CI has not been adjusted for multiplicity, and they should not be used in place of hypothesis testing.
Abbreviation: RP, rescue paramedic.
Due to potential learning effect across successive runs, an exploratory sensitivity analysis was performed. The adjusted difference in time to Transceiver Found between Antenna Search and RP Hoist Search was 142.7 seconds (95% CI, 113.5–171.8; P <0.001) compared with 142.7 seconds (95% CI, 114.3–171.0) in the unadjusted analysis. There was no significant linear trend in time to Transceiver Found across successive runs with Antenna Search (+0.11 seconds per run; P = 0.97) or RP Hoist Search (−3.69 seconds per run; P = 0.15). The difference in slopes between the two strategies was also not statistically significant (interaction P = 0.35).
Discussion
This randomized field trial found that the RP Hoist Search was significantly more efficient than the Antenna Search for localizing buried avalanche victims in a typically skier-triggered sized avalanche. While both methods achieved similar times for initial signal acquisition, the RP Hoist Search proved superior in every subsequent phase of the rescue. The SD for all registered timestamps in the RP Hoist group was lower than in the Antenna Search group, suggesting that the hoist method was more consistent across different runs.
A primary advantage of the RP Hoist Search is its integrated, parallel workflow. In the Antenna Search, the process is longer: the crew must first locate the Optimal Signal, deploy a physical marker (flag), and then initiate a second maneuver to hoist the RP down to that marker. In contrast, the RP Hoist Search integrates these steps; the RP is already suspended and active in the search, allowing for an immediate transition from signal optimization to ground deployment.
The significant reduction in the ground phase duration (50 seconds versus 68 seconds) is noteworthy. This suggests that continuous tracking of the signal from a hoist height of five-to-ten meters may provide the RP with a better “spatial awareness” of the signal. The RP arrives on the snow with a “live” continuous track of the signal.
The “Golden 15 Minutes” has long been the target window for successful avalanche rescue.Reference Falk, Brugger and Adler-Kastner2 However, recent evidence suggests that this critical survival phase may have shortened to 10 minutes.Reference Rauch, Brugger and Falk3 For patients in cardiac arrest, it is well documented that the likelihood of survival is inversely associated with resuscitation duration.Reference Goto, Funada and Goto28–Reference Chai, Fordyce and Guan30 In this study, the RP Hoist Search saved more than two minutes (mean 143 seconds), which represents a significant portion of this survival window. Consequently, adopting a more efficient search strategy may therefore influence survival rates.
This study examined the search strategies in a typical skier-triggered avalanche size. However, for larger avalanches, severely cold conditions, or unconfirmed burials, the Antenna Search may be recommended as a primary strategy to limit the RP’s exposure to extreme temperatures.
The strengths of this paper include use of a realistic scenario with an on-duty AW101-helicopter, ensuring that equipment and crew matched actual mission conditions. Using the same crew across all three days controlled for individual skill levels and mitigated training effects that could have biased the result if personnel had rotated. Additionally, stable weather conditions across all trial days provided a consistent external environment for both search strategies. The internal validity was further strengthened by randomizing the active transceiver among six possible locations and randomizing the sequence of search procedures, preventing the crew from memorizing victim locations or associating specific procedures with certain distances.
Limitations
This was a single-center trial, conducted in a controlled, simulated environment and only one transceiver was searched for at every trial run. In a real-world “multiple burial” scenario, signal overlap might increase complexity and affect localization times. Furthermore, while the AW101’s system and stability make the RP Hoist search highly effective, results may vary for smaller SAR helicopters with different hoist configurations or higher vibration levels, or in larger avalanches with large search areas. The findings may not be directly generalizable to all SAR helicopters, but to systems with comparable helicopter, hoist, crew, and training configurations that operate in comparable settings as studied. As this was a trial to compare two search strategies, the trial did not include the time needed to excavate the transceivers, an obvious contributing factor to the total burial time.Reference Genswein, Macias, McIntosh, Reiweger, Hetland and Paal8 Finally, two minutes may not be vital if the total time for the helicopter to reach the avalanche is long. However, the intention for the rescuers in the initial phase is always to save a life, and if survival is still possible, any technique that reduces the total rescue time is worth utilizing.
Conclusions
This randomized, experimental field trial showed that the RP Hoist Search was significantly more efficient than the traditional Antenna Search for localizing buried avalanche victims, reducing total localization time by more than two minutes. Given that survival probability is reduced after 10-15 minutes of burial, this time saving may be clinically significant. The findings support that RP Hoist Search is an effective localization strategy for helicopter SAR services with comparable hoist systems.
Supplementary material
The supplementary material for this article can be found at https://doi.org/10.1017/S1049023X26109200.
Acknowledgements
The authors would like to thank the crew that participated in this study.
Availability of Data and Materials
The dataset used and analyzed is available from the corresponding author on reasonable request.
Author Contributions
JRB: Designed the study and contributed to conduct of study. Drafted the article and prepared the tables and figures. Revised the manuscript and read and approved the final version of the manuscript and agree to be accountable for all aspects of the work.
AS: Contributed to the planning and conduct of the study. Revised the manuscript and read and approved the final version of the manuscript and agree to be accountable for all aspects of the work.
BM: Contributed to the planning and conduct of the study. Revised the manuscript and read and approved the final version of the manuscript and agree to be accountable for all aspects of the work.
KRS: Contributed to the planning and conduct of the study. Revised the manuscript and read and approved the final version of the manuscript and agree to be accountable for all aspects of the work.
MT: Contributed to the planning and conduct of the study. Revised the manuscript and read and approved the final version of the manuscript and agree to be accountable for all aspects of the work.
LC: Contributed to the planning and conduct of the study. Revised the manuscript and read and approved the final version of the manuscript and agree to be accountable for all aspects of the work.
Funding Statement
The contribution from all personnel and investigators is agreed upon without any financial compensation. Funding for open access was provided by the Norwegian Air Ambulance Foundation (Oslo, Norway). The funder had no role in the conceptualization, design, data collection, analysis or preparation of the manuscript.
Competing Interests
JRB: No conflict of interest. AS: No conflict of interest. BM: No conflict of interest. KRS: No conflict of interest. MT: No conflict of interest. LC: No conflict of interest.
Use of AI Technology
During the preparation of this work, the authors used Google Gemini (Google Inc.; Mountain View, California USA) to help create the figures. After using this tool/service, the authors reviewed and edited the content as needed and take full responsibility for the content of the published article.




 Open access

