


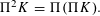
1 Introduction
The setting of this paper is
 $n$
-dimensional Euclidean space
 $\mathbb{R}^{n}$
. A compact convex subset of
 $\mathbb{R}^{n}$
with non-empty interior is called a convex body. The set of convex bodies in
 $\mathbb{R}^{n}$
is denoted by
 $\text{K}^{n}$
. Write
 $\text{K}_{e}^{n}$
for the set of origin-symmetric convex bodies. Also, write
 $B^{n}$
for the unit ball of
 $\mathbb{R}^{n}$
and
 $S^{n-1}$
for the unit sphere of
 $\mathbb{R}^{n}$
.
The support function of
 $K\in \text{K}^{n}$
,
 $h_{K}:S^{n-1}\rightarrow \mathbb{R}$
, is defined by
 $$\begin{eqnarray}h_{K}(u):=\max _{x\in K}x\cdot u.\end{eqnarray}$$
The space of support functions of bodies in
 $\text{K}_{e}^{n}$
is denoted by
 $\text{S}_{e}^{n}.$
Let
 $K$
be a convex body in
 $\mathbb{R}^{n}$
,
 $n\geqslant 3.$
The projection body
 $\unicode[STIX]{x1D6F1}K$
of
 $K$
is the origin-symmetric convex body whose support function is given by
 $$\begin{eqnarray}h_{\unicode[STIX]{x1D6F1}K}(u)=V_{n-1}(K|u^{\bot })\end{eqnarray}$$
for all
 $u\in S^{n-1}$
. Here
 $V_{n-1}(K|u^{\bot })$
is the
 $(n-1)$
-dimensional Lebesgue measure of the orthogonal projection of
 $K$
onto the subspace
 $u^{\bot }=\{x\in \mathbb{R}^{n};x\cdot u=0\}$
.
Petty’s conjectured projection inequality states that for
 $n\geqslant 3$
the minimum of the affine invariant quantity
 ${\mathcal{P}}(K):=V(\unicode[STIX]{x1D6F1}K)/V(K)^{n-1}$
is attained precisely by ellipsoids; cf. [Reference Lutwak12, Reference Lutwak, Gruber and Wills14, Reference Petty and Fenchel16, Reference Petty17]. Here
 $V(K)$
is the
 $n$
-dimensional Lebesgue measure of
 $K.$
As Schneider [Reference Schneider19, p. 570] observes, if
 $K$
minimizes
 ${\mathcal{P}}$
then
 $\unicode[STIX]{x1D6F1}^{2}K=cK+\vec{a}$
for some constant
 $c$
and vector
 $\vec{a}\in \mathbb{R}^{n};$
therefore, the classification of solutions to
 $\unicode[STIX]{x1D6F1}^{2}K=cK$
is of major interest; see also [Reference Lutwak, Gruber and Wills14, Problem 12.7] and [Reference Gardner4, Problems 4.5 and 4.6]. Note that
 $\unicode[STIX]{x1D6F1}B^{n}=\unicode[STIX]{x1D714}_{n-1}B^{n}$
and
 $\unicode[STIX]{x1D6F1}^{2}B^{n}=\unicode[STIX]{x1D714}_{n-1}^{n}B^{n},$
where
 $\unicode[STIX]{x1D714}_{k}$
is the volume of
 $B^{k}$
. Thus, in view of
 $\unicode[STIX]{x1D6F1}(\unicode[STIX]{x1D719}K)=|\text{det}\,\unicode[STIX]{x1D719}|\unicode[STIX]{x1D719}^{-t}(\unicode[STIX]{x1D6F1}K)$
for any
 $\unicode[STIX]{x1D719}\in \operatorname{Gl}_{n}$
Footnote
1
(see, e.g., [Reference Gardner4, Theorem 4.1.5]), any origin-centered ellipsoid is also a solution. Weil [Reference Weil22] proved that the only polytopes that solve
 $\unicode[STIX]{x1D6F1}^{2}K=cK+\vec{a}$
are the direct sums of centrally symmetric polygons or segments. In view of Weil’s result, to use the inverse function theorem on Banach spaces effectively, we restrict our attention to convex solutions with support functions of class
 $C^{2}$
.
Theorem. Suppose that
 $n\geqslant 3.$
There exists
 $\unicode[STIX]{x1D700}>0$
with the following property. If
 $\unicode[STIX]{x1D6F1}^{2}K=cK$
for some
 $c>0$
,
 $h_{K}\in C^{2}(S^{n-1})$
and
 $\Vert h_{\unicode[STIX]{x1D719}K}-1\Vert _{C^{2}}\leqslant \unicode[STIX]{x1D700}$
for some
 $\unicode[STIX]{x1D719}\in \operatorname{Gl}_{n}$
, then
 $K$
is an origin-centered ellipsoid.
Let us note that this result also follows from the recent work of Saroglou and Zvavitch [Reference Saroglou and Zvavitch18]; see also Remark 4.4. It would be unfair if we do not mention the work of Fish et al [Reference Fish, Nazarov, Ryabogin and Zvavitch3], where the idea of considering the iteration problems locally was initiated. In [Reference Fish, Nazarov, Ryabogin and Zvavitch3], Fish et al treated a similar question to the one considered here for iterations of the intersection body operator; the proof of Saroglou and Zvavitch is an adaption of the argument of [Reference Fish, Nazarov, Ryabogin and Zvavitch3]. We believe that the techniques of [Reference Fish, Nazarov, Ryabogin and Zvavitch3, Reference Saroglou and Zvavitch18] apply to several other open problems and that our method here also applies to many other open problems such as the second mixed projection problem, the second mixed intersection problem and the projection centroid conjectures [Reference Gardner4, Reference Lutwak, Gruber and Wills14] and yields local uniqueness theorems similar to the main theorem here. Due to notational complexity which would result in loss of clarity in exposition, we decided to treat these aforementioned problems elsewhere.
For the definitions of
 $W_{n-2}$
and
 $\unicode[STIX]{x1D6F1}_{n-2}$
, we refer the reader to (5.1) and (5.2). In [Reference Saroglou and Zvavitch18], the authors proved a strengthened version of Lutwak’s inequality (cf. [Reference Lutwak13]):
 $$\begin{eqnarray}\displaystyle W_{n-2}(\unicode[STIX]{x1D6F1}_{n-2}K)-\frac{n(n-2)\unicode[STIX]{x1D714}_{n-1}^{2}}{(n-1)^{2}\unicode[STIX]{x1D714}_{n}}W_{n-1}^{2}(K)-\frac{\unicode[STIX]{x1D714}_{n-1}^{2}}{(n-1)^{2}}W_{n-2}(K)\geqslant 0.\quad & & \displaystyle\end{eqnarray}$$
Furthermore, they conjectured that equality holds only for balls. In §5, we give a direct proof of this inequality and we prove that the equality holds precisely for convex bodies whose support functions lie in the linear span of spherical harmonics of degree less than or equal to two; see [Reference Groemer7, Theorem 5.7.4] for a geometric interpretation of such convex bodies.
2 Background
In this section, we collect several standard definitions and facts from convex geometry. Most of the material here is taken from [Reference Gardner4, Reference Groemer7, Reference Schneider19].
A convex body is said to be of class
 $C_{+}^{2}$
if its boundary hypersurface is two times continuously differentiable, in the sense of differential geometry, and the Gauss map
 $\unicode[STIX]{x1D708}:\unicode[STIX]{x2202}K\rightarrow S^{n-1}$
, which takes
 $x$
on the boundary of
 $K$
to its unique outer unit normal vector
 $\unicode[STIX]{x1D708}(x)$
, is well defined and a
 $C^{1}$
-diffeomorphism.
2.1 Mixed volume, mixed surface area measure and mixed projection
Let
 $K,L$
be two convex bodies and
 $0<t<\infty$
. The Minkowski sum
 $K+tL$
is defined by
 $h_{K+tL}:=h_{K}+th_{L}$
and the mixed volume
 $V_{1}(K,L)$
of
 $K$
and
 $L$
is defined by
 $$\begin{eqnarray}V_{1}(K,L):=\frac{1}{n}\lim _{t\rightarrow 0^{+}}\frac{V(K+tL)-V(K)}{t}.\end{eqnarray}$$
A fundamental fact is that corresponding to each convex body
 $K$
, there is a unique Borel measure
 $S(K,\cdot )$
on the unit sphere such that
 $$\begin{eqnarray}V_{1}(K,L)=\frac{1}{n}\int _{S^{n-1}}h_{L}(u)\,dS(K,u)\end{eqnarray}$$
for any convex body
 $L$
. The measure
 $S(K,\cdot )$
is called the surface area measure of
 $K.$
A convex body
 $K$
is said to have a positive continuous curvature function
 $f_{K}$
, defined on the unit sphere, provided that for each convex body
 $L$
,
 $$\begin{eqnarray}V_{1}(K,L)=\frac{1}{n}\int _{S^{n-1}}h_{L}f_{K}\,dx,\end{eqnarray}$$
where
 $dx$
is the spherical Lebesgue measure on
 $S^{n-1}.$
A convex body can have at most one curvature function; see [Reference Bonnesen and Fenchel2, p. 115]. If
 $K$
is of class
 $C_{+}^{2}$
, then
 $S_{K}$
is absolutely continuous with respect to
 $x$
, and the Radon–Nikodym derivative
 $dS_{K}/dx:S^{n-1}\rightarrow \mathbb{R}$
is the reciprocal Gauss curvature of
 $\unicode[STIX]{x2202}K$
(viewed as a function of the outer unit normal vectors) given by
 $f_{K}$
. For every
 $K\in \text{K}^{n},$
 $V(K)=V_{1}(K,K).$
The mixed volume
 $V(K_{1},\ldots ,K_{n})$
and mixed area measure
 $S(K_{1},\ldots ,K_{n-1},\cdot )$
of the compact convex subsets
 $K_{1},\ldots ,K_{n}$
of
 $\mathbb{R}^{n}$
are respectively defined by
 $$\begin{eqnarray}\displaystyle & \displaystyle V(K_{1},\ldots ,K_{n}):=\frac{1}{n!}\mathop{\sum }_{j=1}^{n}(-1)^{n+j}\mathop{\sum }_{i_{1}<\cdots <i_{j}}V(K_{i_{1}}+\cdots +K_{i_{j}}), & \displaystyle \nonumber\\ \displaystyle & \displaystyle S(K_{1},\ldots ,K_{n-1},\cdot ):=\frac{1}{(n-1)!}\mathop{\sum }_{j=1}^{n-1}(-1)^{n+j-1}\mathop{\sum }_{i_{1}<\cdots <i_{j}}S(K_{i_{1}}+\cdots +K_{i_{j}},\cdot ). & \displaystyle \nonumber\end{eqnarray}$$
Furthermore, they are related by
 $$\begin{eqnarray}V(K_{1},\ldots ,K_{n})=\frac{1}{n}\int _{S^{n-1}}h_{K_{n}}(u)\,dS(K_{1},\ldots ,K_{n-1},u).\end{eqnarray}$$
For real symmetric
 $(n-1)\times (n-1)$
matrices
 $A_{1},\ldots ,A_{n-1}$
, write
 $D(A_{1},\ldots ,A_{n-1})$
for their mixed discriminant; see [Reference Schneider19, (2.64) and (5.117)]. Let
 $S_{n-1}$
be the group of all permutations of the set
 $\{1,\ldots ,n-1\}$
and let
 $\unicode[STIX]{x1D700}:S_{n-1}\rightarrow \{-1,1\}$
be defined by
 $\unicode[STIX]{x1D700}(\unicode[STIX]{x1D70E})=1$
 $(-1)$
if
 $\unicode[STIX]{x1D70E}$
is even (odd). The mixed discriminant of functions
 $f_{i}\in C^{2}(S^{n-1}),1\leqslant i\leqslant n-1,$
is a multilinear operator defined as
 $$\begin{eqnarray}\displaystyle {\mathcal{Q}}(f_{1},\ldots ,f_{n-1}) & := & \displaystyle D(A[f_{1}],\ldots ,A[f_{n-1}])\nonumber\\ \displaystyle & = & \displaystyle \frac{1}{(n-1)!}\mathop{\sum }_{\unicode[STIX]{x1D6FF},\unicode[STIX]{x1D70F}\in S_{n-1}}\unicode[STIX]{x1D700}(\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D70F})\mathop{\prod }_{i=1}^{n-1}(A[f_{i}])_{\unicode[STIX]{x1D6FF}(i)\unicode[STIX]{x1D70F}(i)},\end{eqnarray}$$
where in a local orthonormal frame of
 $S^{n-1}$
the entries of the matrix
 $A[f_{k}]$
are given by
 $(A[f_{k}])_{ij}=\unicode[STIX]{x1D6FB}_{i}\unicode[STIX]{x1D6FB}_{j}f_{k}+\unicode[STIX]{x1D6FF}_{ij}f_{k}$
and
 $\unicode[STIX]{x1D6FB}$
is the covariant derivative on
 $S^{n-1}.$
The operator
 ${\mathcal{Q}}$
enjoys several important properties; for example, it is independent of the order of its arguments; see [Reference Andrews1, Lemma 2-12].
Remark 2.1. Suppose that
 $f,g\in C^{2}(S^{n-1}).$
For convenience, we will put
 $$\begin{eqnarray}\displaystyle & \displaystyle \Box f:=\unicode[STIX]{x1D6E5}f+(n-1)f,\qquad {\mathcal{Q}}(f):={\mathcal{Q}}(f,\ldots ,f), & \displaystyle \nonumber\\ \displaystyle & \displaystyle {\mathcal{Q}}_{1}(f,g):={\mathcal{Q}}(f,\ldots ,f,g). & \displaystyle \nonumber\end{eqnarray}$$
Note that
 ${\mathcal{Q}}(f)=\det (A[f])$
and a simple calculation shows that
 ${\mathcal{Q}}_{1}(1,f)=(1/(n-1))\Box f$
.
Let
 $K$
and
 $K_{i}$
be
 $C_{+}^{2}$
convex bodies. Using [Reference Schneider19, (2.68) and (5.48)], for any Borel set
 $\unicode[STIX]{x1D714}\subset S^{n-1}$
, we have
 $$\begin{eqnarray}\displaystyle & \displaystyle S(K_{1},\ldots ,K_{n-1},\unicode[STIX]{x1D714})=\int _{\unicode[STIX]{x1D714}}{\mathcal{Q}}(h_{K_{1}},\ldots ,h_{K_{n-1}})(x)\,dx, & \displaystyle \nonumber\\ \displaystyle & \displaystyle S(B^{n},\ldots ,B^{n},K,\unicode[STIX]{x1D714})=\frac{1}{n-1}\int _{\unicode[STIX]{x1D714}}\Box h_{K}(x)\,dx. & \displaystyle \nonumber\end{eqnarray}$$
The mixed projection
 $\unicode[STIX]{x1D6F1}(K_{1},\ldots ,K_{n-1})$
of convex bodies
 $K_{1},\ldots ,K_{n-1}$
is a convex body whose support function is given by
 $$\begin{eqnarray}\displaystyle h_{\unicode[STIX]{x1D6F1}(K_{1},\ldots ,K_{n-1})}(u) & := & \displaystyle V_{n-1}(K_{1}|u^{\bot },\ldots ,K_{n-1}|u^{\bot })\nonumber\\ \displaystyle & = & \displaystyle \frac{1}{2}\int _{S^{n-1}}|u\cdot v|\,dS(K_{1},\ldots ,K_{n-1},v)\nonumber\\ \displaystyle & = & \displaystyle nV(K_{1},\ldots ,K_{n-1},\bar{u}),\nonumber\end{eqnarray}$$
where
 $\bar{u}$
is the segment joining
 $-u/2$
and
 $u/2$
; see [Reference Schneider19, p. 570].
Remark 2.2. For simplicity, we write
 $$\begin{eqnarray}\unicode[STIX]{x1D6F1}(K,\ldots ,K,L)=\unicode[STIX]{x1D6F1}_{1}(K,L).\end{eqnarray}$$
2.2 Spherical harmonics
Write
 $L^{2}(S^{n-1})$
for the Hilbert space of square-integrable real functions on
 $S^{n-1}$
equipped with the scalar product
 $$\begin{eqnarray}(f,g):=\int _{S^{n-1}}fg\,dx.\end{eqnarray}$$
The induced norm by this scalar product is symbolized by
 $\Vert \cdot \Vert _{2}.$
Spherical harmonics of degree
 $k$
are eigenfunctions of the spherical Laplace operator
 $\unicode[STIX]{x1D6E5}$
with the eigenvalue
 $k(k+n-2).$
In fact, if
 $Y_{k}$
is such a function, then
 $$\begin{eqnarray}\unicode[STIX]{x1D6E5}Y_{k}=-k(k+n-2)Y_{k}.\end{eqnarray}$$
The set
 ${\mathcal{S}}^{k}$
of spherical harmonics of degree
 $k$
is a vector subspace of
 $C(S^{n-1}).$
Moreover,
 $\operatorname{dim}{\mathcal{S}}^{k}=N(n,k):=(2k+n-2)/(k+n-2)\binom{k+n-2}{k}.$
In each space
 ${\mathcal{S}}^{k},$
choose an orthonormal basis
 $\{Y_{k,1},\ldots ,Y_{k,N(n,k)}\}$
. Note that
 $$\begin{eqnarray}Y_{0,1}=\frac{1}{\sqrt{n\unicode[STIX]{x1D714}_{n}}}.\end{eqnarray}$$
For
 $f\in L^{2}(S^{n-1})$
, we write
 $$\begin{eqnarray}\unicode[STIX]{x1D70B}_{k}f:=\mathop{\sum }_{l=1}^{N(n,k)}(f,Y_{k,l})Y_{k,l},\qquad \unicode[STIX]{x1D70B}_{0}f=\frac{1}{n\unicode[STIX]{x1D714}_{n}}\int _{S^{n-1}}f\,dx.\end{eqnarray}$$
The condensed harmonic expansion of
 $f$
is given by
 $$\begin{eqnarray}f\sim \mathop{\sum }_{k=0}^{\infty }\unicode[STIX]{x1D70B}_{k}f;\end{eqnarray}$$
it converges to
 $f$
in the
 $L^{2}(S^{n-1})$
-norm. In addition, for
 $f,g\in L^{2}(S^{n-1})$
, we have
 $$\begin{eqnarray}\mathop{\sum }_{k=0}^{\infty }\mathop{\sum }_{l=1}^{N(n,k)}(f,Y_{k,l})(g,Y_{k,l})=(f,g).\end{eqnarray}$$
Note that
 $f\in L^{2}(S^{n-1})$
if and only if its condensed harmonic expansion satisfies
 $$\begin{eqnarray}\mathop{\sum }_{k=0}^{\infty }\Vert \unicode[STIX]{x1D70B}_{k}f\Vert _{2}^{2}<\infty .\end{eqnarray}$$
One can read more about spherical harmonics in [Reference Groemer7].
2.3 Radon transform and cosine transform
Suppose that
 $f$
is a Borel function on
 $S^{n-1}.$
The spherical Radon transform (also known as the Funk transform; see, for example, [Reference Helgason9]) and cosine transform of
 $f$
are defined as follows:
 $$\begin{eqnarray}\displaystyle {\mathcal{R}}f(u):=\frac{1}{(n-1)\unicode[STIX]{x1D714}_{n-1}}\int _{S^{n-1}\cap u^{\bot }}f(x)\,dx,\qquad {\mathcal{C}}f(u):=\int _{S^{n-1}}|u\cdot x|f(x)\,dx. & & \displaystyle \nonumber\end{eqnarray}$$
We normalized
 ${\mathcal{R}}$
so that
 ${\mathcal{R}}1=1.$
The transformations
 ${\mathcal{R}}$
and
 ${\mathcal{C}}$
are self-adjoint, in the sense that if
 $f$
and
 $g$
are bounded Borel functions on
 $S^{n-1},$
then
 $$\begin{eqnarray}\displaystyle & \displaystyle \int _{S^{n-1}}f(x){\mathcal{R}}g(x)\,dx=\int _{S^{n-1}}g(x){\mathcal{R}}f(x)\,dx, & \displaystyle \nonumber\\ \displaystyle & \displaystyle \int _{S^{n-1}}f(x){\mathcal{C}}g(x)\,dx=\int _{S^{n-1}}g(x){\mathcal{C}}f(x)\,dx. & \displaystyle \nonumber\end{eqnarray}$$
For a continuous function
 $f\in C(S^{n-1})$
, the explicit expressions for the first and second derivatives of
 ${\mathcal{C}}f$
are given in [Reference Martinez-Maure15, Theorem 1 and Lemma 1]: let
 $f$
be a continuous function on
 $S^{n-1}.$
Then the positively 1-homogeneous function
 $$\begin{eqnarray}\displaystyle h:\mathbb{R}^{n}\rightarrow \mathbb{R},\qquad p\mapsto \int _{S^{n-1}}|p\cdot x|f(x)\,dx, & & \displaystyle \nonumber\end{eqnarray}$$
is of class
 $C^{2}$
on
 $\mathbb{R}^{n}-\{0\}.$
Its first differential and second differential at
 $p,$
considered as a bilinear form on
 $\mathbb{R}^{n},$
are given by
 $$\begin{eqnarray}\displaystyle \begin{array}{@{}c@{}}\displaystyle d_{p}h=\int _{S^{n-1}}\operatorname{sgn}(x\cdot p)xf(x)\,dx,\\ \displaystyle d_{p}^{2}h(x,y)=\frac{2}{\Vert p\Vert }\int _{S^{n-1}\cap p^{\bot }}(q\cdot x)(q\cdot y)f(q)\,dq\end{array} & & \displaystyle\end{eqnarray}$$
for all
 $x,y\in \mathbb{R}^{n}$
.
Identities (2.2) imply that if for a sequence
 $\{f_{i}\}_{i}\subset C(S^{n-1})$
,
 $f_{i}\rightarrow _{C}f\in C(S^{n-1})$
, then
 ${\mathcal{C}}f_{i}\rightarrow _{C^{2}}{\mathcal{C}}f\in C^{2}(S^{n-1}).$
Thus,
 ${\mathcal{C}}:C(S^{n-1})\rightarrow C^{2}(S^{n-1})$
is a continuous linear map from a Banach space to a Banach space; therefore, it is bounded. That is, there exists a constant
 $c_{n}>0$
such that for any
 $f\in C(S^{n-1})$
, we have
 $$\begin{eqnarray}\displaystyle \Vert {\mathcal{C}}f\Vert _{C^{2}}\leqslant c_{n}\Vert f\Vert _{C}. & & \displaystyle\end{eqnarray}$$
The following relation between Radon transform and cosine transform is established in [Reference Goodey and Weil6, Proposition 2.1]:
 $$\begin{eqnarray}\displaystyle \Box {\mathcal{C}}=2(n-1)\unicode[STIX]{x1D714}_{n-1}{\mathcal{R}}. & & \displaystyle\end{eqnarray}$$
Let
 $H^{s}(S^{n-1}),$
 $s\geqslant 0$
, be the spaces of those functions for which the spherical harmonic expansion satisfies
 $\Vert f\Vert _{H^{s}}^{2}:=\sum _{k=0}^{\infty }(1+k^{2})^{s}\Vert \unicode[STIX]{x1D70B}_{k}f\Vert _{2}^{2}<\infty .$
The following results about the smoothing property of
 ${\mathcal{R}},{\mathcal{C}}$
are proved in [Reference Strichartz21]:
 $$\begin{eqnarray}\displaystyle \Vert {\mathcal{R}}f\Vert _{H^{s+(n-2)/2}}\leqslant a_{s,n}\Vert f\Vert _{H^{s}},\qquad \Vert {\mathcal{C}}f\Vert _{H^{s+(n+2)/2}}\leqslant b_{s,n}\Vert f\Vert _{H^{s}} & & \displaystyle\end{eqnarray}$$
for some positive constants depending on
 $s$
and
 $n$
. Let us put
 $$\begin{eqnarray}H_{e}^{s}(S^{n-1}):=\{f\in H^{s}(S^{n-1});f(x)=f(-x)\text{ for all }x\in S^{n-1}\}.\end{eqnarray}$$
Strichartz proved that
 $H_{e}^{s}(S^{n-1})$
is precisely the space of even functions
 $f\in L^{2}(S^{n-1})$
with derivatives up to order
 $s$
in
 $L^{2}(S^{n-1});$
see [Reference Strichartz21, pp. 721–722]. Hence,
 $H_{e}^{s}(S^{n-1})$
,
 $s\geqslant 0$
, are Sobolev spaces.
3 A local diffeomorphism
Define a map by
 $$\begin{eqnarray}\displaystyle {\mathcal{X}}_{m}:\text{S}_{e}^{n} & \rightarrow C_{e}(S^{n-1}),\qquad h_{K}\mapsto -h_{\unicode[STIX]{x1D6F1}^{2m}K}+\biggl(\frac{V(\unicode[STIX]{x1D6F1}^{2m}K)}{V(K)}\biggr)^{1/n}h_{K}. & \displaystyle \nonumber\end{eqnarray}$$
Clearly,
 ${\mathcal{X}}_{m}$
is a continuous nonlinear map.
Remark 3.1. Let
 $\tilde{U}$
be a
 $C_{e}^{2}(S^{n-1})$
-neighborhood of
 $0$
such that for every
 $f\in \tilde{U} ,$
 $1+f>0$
and the matrix
 $A[1+f]$
is positive definite. Thus, for each
 $f\in \tilde{U} ,$
 $1+f$
represents the support function of an origin-symmetric convex body of class
 $C_{+}^{2}.$
Also note that if
 $K$
is of class
 $C_{+}^{2}$
, then
 $\unicode[STIX]{x1D6F1}^{k}K$
is also of class
 $C_{+}^{2};$
see [Reference Martinez-Maure15, p. 13]. Putting these two facts together implies that
 ${\mathcal{X}}_{m}(1+\cdot )$
maps
 $\tilde{U}$
to a subset of
 $C_{e}^{2}(S^{n-1}).$
To employ the inverse function theorem, it is convenient to work with the map
 $$\begin{eqnarray}\displaystyle & \displaystyle {\mathcal{Y}}_{m}:\tilde{U} \subset C_{e}^{2}(S^{n-1})\rightarrow C_{e}^{2}(S^{n-1}), & \displaystyle \nonumber\\ \displaystyle & \displaystyle {\mathcal{Y}}_{m}(f):={\mathcal{X}}_{m}(1+f). & \displaystyle \nonumber\end{eqnarray}$$
The derivative of
 ${\mathcal{Y}}_{m}:\tilde{U} \subset C_{e}^{2}(S^{n-1})\rightarrow C_{e}^{2}(S^{n-1})$
at the point
 $f\in \tilde{U}$
in the direction
 $g\in C_{e}^{2}(S^{n-1})$
is defined by
 $$\begin{eqnarray}\lim _{t\rightarrow 0}\biggl\|\frac{{\mathcal{Y}}_{m}(f+tg)-{\mathcal{Y}}_{m}(f)}{t}-D{\mathcal{Y}}_{m}(f,g)\biggr\|_{C^{2}}=0.\end{eqnarray}$$
Similar definitions apply to the higher derivatives. The
 $(k+1)$
th derivative is defined by induction:
 $$\begin{eqnarray}\displaystyle & \displaystyle D^{k+1}{\mathcal{Y}}_{m}:\tilde{U} \times (C_{e}^{2}(S^{n-1}))^{(k+1)}\rightarrow C_{e}^{2}(S^{n-1}), & \displaystyle \nonumber\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & & \displaystyle D^{k+1}{\mathcal{Y}}_{m}(f,g_{1},\ldots ,g_{k+1})\nonumber\\ \displaystyle & & \displaystyle \quad =\lim _{t\rightarrow 0}\frac{D^{k}{\mathcal{Y}}_{m}(f+tg_{k+1},g_{1},\ldots ,g_{k})-D^{k}{\mathcal{Y}}_{m}(f,g_{1},\ldots ,g_{k})}{t}.\nonumber\end{eqnarray}$$
The limit is taken in the
 $C^{2}$
-norm. We prove that
 ${\mathcal{Y}}_{m}$
is smooth; that is:
-
(1)
 ${\mathcal{Y}}_{m}$
is continuous;
-
(2) the limits above exist for all
$k\geqslant 0,$
$f\in \tilde{U}$
and
$$\begin{eqnarray}(g_{1},\ldots ,g_{k+1})\in (C_{e}^{2}(S^{n-1}))^{(k+1)}=\underbrace{C_{e}^{2}(S^{n-1})\times \cdots \times C_{e}^{2}(S^{n-1})}_{k+1\text{ times}};\end{eqnarray}$$
-
(3)
$D^{k+1}{\mathcal{Y}}_{m}$
is continuous jointly as a function on the product space.


There is a large difference in what it means for
 $D{\mathcal{Y}}_{m}:\tilde{U} \times C_{e}^{2}(S^{n-1})\rightarrow C_{e}^{2}(S^{n-1})$
to be continuous, as opposed to
 $D{\mathcal{Y}}_{m}:\tilde{U} \subset C_{e}^{2}(S^{n-1})\rightarrow L(C_{e}^{2}(S^{n-1}),C_{e}^{2}(S^{n-1}))$
(thus, our continuity assumption is weaker and easier to check); see [Reference Hamilton8, Definition 3.1.1].
Then we continue by providing the explicit expression of
 $D{\mathcal{Y}}_{m}(0,\cdot )$
and a description of
 $\operatorname{Ker}D{\mathcal{Y}}_{m}(0,\cdot ).$
The description of the kernel yields that
 $$\begin{eqnarray}D{\mathcal{Y}}_{m}(0,\cdot )+\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{2}:C_{e}^{2}(S^{n-1})\rightarrow C_{e}^{2}(S^{n-1})\end{eqnarray}$$
is an isomorphism, so by the inverse function theorem (see [Reference Hamilton8, Theorem 5.2.3]) there are open neighborhoods
 $U,W$
of
 $0$
in
 $C_{e}^{2}(S^{n-1})$
such that the map
 $$\begin{eqnarray}\displaystyle {\mathcal{N}}:U\subset \tilde{U} & \rightarrow W\subset C_{e}^{2}(S^{n-1}),\qquad f\mapsto {\mathcal{Y}}_{m}(f)+(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{2})f & \displaystyle \nonumber\end{eqnarray}$$
is a smooth diffeomorphism.
Lemma 3.2. For
 $K\in \text{K}_{e}^{n}$
of class
 $C_{+}^{2}$
and
 $g\in C_{e}^{2}(S^{n-1})$
, we have
 $$\begin{eqnarray}\displaystyle & & \displaystyle \left.\frac{d}{dt}\right|_{t=0}h_{\unicode[STIX]{x1D6F1}^{k}(h_{K}+tg)}\nonumber\\ \displaystyle & & \displaystyle \quad =\frac{(n-1)^{k}}{2^{k}}{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-1}K},{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-2}K},{\mathcal{C}}{\mathcal{Q}}_{1}(\ldots ,{\mathcal{C}}{\mathcal{Q}}_{1}(h_{K},g)\cdots \,))),\nonumber\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \left.\frac{d}{dt}\right|_{t=0}h_{\unicode[STIX]{x1D6F1}^{k}(1+tg)}=\frac{(V(\unicode[STIX]{x1D6F1}^{k}B^{n})/V(B^{n}))^{1/n}}{2^{k}\unicode[STIX]{x1D714}_{n-1}^{k}}({\mathcal{C}}\Box )^{(k)}g, & \displaystyle \nonumber\end{eqnarray}$$
where
 $({\mathcal{C}}\Box )^{(k)}g:=\underbrace{{\mathcal{C}}\Box \ldots {\mathcal{C}}\Box }_{k\text{ times}}g.$
Proof. In this proof,
 $f=g+o(t^{l},k)$
means that
 $\Vert f-g\Vert _{C^{k}}\leqslant ct^{l}$
for some
 $c>0.$
Take
 $t$
sufficiently small so that
 $h_{K}+tg$
is the support function of a
 $C_{+}^{2}$
convex body, which we denote also by
 $h_{K}+tg$
. By (2.1), we have
 $$\begin{eqnarray}{\mathcal{Q}}(h_{K}+tg,\ldots ,h_{K}+tg)={\mathcal{Q}}(h_{K})+(n-1)t{\mathcal{Q}}_{1}(h_{K},g)+o(t^{2},0).\end{eqnarray}$$
Hence, in view of the definition of mixed projection and (2.3), we get
 $$\begin{eqnarray}\displaystyle h_{\unicode[STIX]{x1D6F1}(h_{K}+tg)}=h_{\unicode[STIX]{x1D6F1}K}+\frac{t(n-1)}{2}{\mathcal{C}}{\mathcal{Q}}_{1}(h_{K},g)+o(t^{2},2). & & \displaystyle \nonumber\end{eqnarray}$$
If
 $t$
is small enough, then
 $h_{\unicode[STIX]{x1D6F1}(h_{K}+tg)}$
also represents a
 $C_{+}^{2}$
convex body, so
 $$\begin{eqnarray}\displaystyle h_{\unicode[STIX]{x1D6F1}^{2}(h_{K}+tg)}=h_{\unicode[STIX]{x1D6F1}^{2}K}+\frac{t(n-1)^{2}}{4}{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}K},{\mathcal{C}}{\mathcal{Q}}_{1}(h_{K},g))+o(t^{2},2). & & \displaystyle \nonumber\end{eqnarray}$$
By induction and (2.3), for
 $t$
small enough, we obtain
 $$\begin{eqnarray}\displaystyle & & \displaystyle \frac{h_{\unicode[STIX]{x1D6F1}^{k}(h_{K}+tg)}-h_{\unicode[STIX]{x1D6F1}^{k}K}}{t}\nonumber\\ \displaystyle & & \displaystyle \quad =\frac{(n-1)^{k}}{2^{k}}{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-1}K},{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-2}K},{\mathcal{C}}{\mathcal{Q}}_{1}(\ldots ,{\mathcal{C}}{\mathcal{Q}}_{1}(h_{K},g)\cdots \,)))\nonumber\\ \displaystyle & & \displaystyle \qquad +\,o(t,2).\end{eqnarray}$$
This proves the first assertion. For
 $K=B^{n},$
(3.2) yields
 $$\begin{eqnarray}\displaystyle h_{\unicode[STIX]{x1D6F1}^{k}(1+tg)}=h_{\unicode[STIX]{x1D6F1}^{k}B^{n}}+\frac{t}{2^{k}}\biggl(\mathop{\prod }_{i=1}^{k}c_{i}\biggr)^{n-2}({\mathcal{C}}\Box )^{(k)}g+o(t^{2},2), & & \displaystyle \nonumber\end{eqnarray}$$
where
 $c_{i}$
are defined through
 $c_{1}=1$
and
 $\unicode[STIX]{x1D6F1}^{i-1}B^{n}=c_{i}B^{n}.$
So we need to verify that
 $$\begin{eqnarray}\biggl(\mathop{\prod }_{i=1}^{k}c_{i}\biggr)^{n-2}=\frac{(V(\unicode[STIX]{x1D6F1}^{k}B^{n})/V(B^{n}))^{1/n}}{\unicode[STIX]{x1D714}_{n-1}^{k}}.\end{eqnarray}$$
We prove the claim by induction. The claim clearly holds for
 $k=1.$
Suppose for some
 $k\geqslant 1$
,
 $(\prod _{i=1}^{k}c_{i})^{n-2}=((V(\unicode[STIX]{x1D6F1}^{k}B^{n})/V(B^{n}))^{1/n})/\unicode[STIX]{x1D714}_{n-1}^{k}.$
Hence, we see that
 $$\begin{eqnarray}\biggl(\mathop{\prod }_{i=1}^{k+1}c_{i}\biggr)^{n-2}=\frac{(V(\unicode[STIX]{x1D6F1}^{k}B^{n})/V(B^{n}))^{1/n}}{\unicode[STIX]{x1D714}_{n-1}^{k}}c_{k+1}^{n-2}.\end{eqnarray}$$
Since
 $\unicode[STIX]{x1D6F1}^{k}B^{n}=c_{k+1}B^{n},$
we get
 $(\prod _{i=1}^{k+1}c_{i})^{n-2}=c_{k+1}^{n-1}/\unicode[STIX]{x1D714}_{n-1}^{k}.$
Also, we have
 $c_{k+2}=c_{k+1}^{n-1}\unicode[STIX]{x1D714}_{n-1};$
therefore, we arrive at
 $$\begin{eqnarray}\biggl(\mathop{\prod }_{i=1}^{k+1}c_{i}\biggr)^{n-2}=\frac{c_{k+2}}{\unicode[STIX]{x1D714}_{n-1}^{k+1}}\Rightarrow \biggl(\mathop{\prod }_{i=1}^{k+1}c_{i}\biggr)^{n-2}=\frac{(V(\unicode[STIX]{x1D6F1}^{k+1}B^{n})/V(B^{n}))^{1/n}}{\unicode[STIX]{x1D714}_{n-1}^{k+1}}.\Box\end{eqnarray}$$
Remark 3.3. The following remarks are in order.
-
(1) In Lemma 3.2, since
$g\in C_{e}^{2}(S^{n-1})$
, we have
$({\mathcal{C}}\Box )^{(k)}g\in C_{e}^{2}(S^{n-1})$
; see [Reference Martinez-Maure15]. -
(2) Let us put
Using Lemma 3.2, we have
$$\begin{eqnarray}\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k}K}(g):=\frac{d}{dt}\bigg|_{t=0}h_{\unicode[STIX]{x1D6F1}^{k}(h_{K}+tg)},\qquad \unicode[STIX]{x1D6FD}_{\unicode[STIX]{x1D6F1}^{k}K}(g):=\frac{d}{dt}\bigg|_{t=0}f_{\unicode[STIX]{x1D6F1}^{k}(h_{K}+tg)}.\end{eqnarray}$$
(3.3)
$$\begin{eqnarray}\displaystyle \begin{array}{@{}ccl@{}}\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}K}(g)\, & =\, & \displaystyle \frac{n-1}{2}{\mathcal{C}}{\mathcal{Q}}_{1}(h_{K},g),\\ \unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k}K}(g)\, & =\, & \displaystyle \frac{n-1}{2}{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-1}K},\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k-1}K}(g)),\\ \unicode[STIX]{x1D6FD}_{\unicode[STIX]{x1D6F1}^{k}K}(g)\, & =\, & \displaystyle (n-1){\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k}K},\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k}K}(g)).\end{array} & & \displaystyle\end{eqnarray}$$


Lemma 3.4. For
 $K\in \text{K}_{e}^{n}$
of class
 $C_{+}^{2}$
and
 $g\in C_{e}^{2}(S^{n-1})$
, we have
 $$\begin{eqnarray}\displaystyle & & \displaystyle \left.\frac{d}{dt}\right|_{t=0}V(\unicode[STIX]{x1D6F1}^{k}(h_{K}+tg))\nonumber\\ \displaystyle & & \displaystyle \quad =\frac{(n-1)^{k}}{2^{k-1}}\nonumber\\ \displaystyle & & \displaystyle \qquad \times \,\int _{S^{n-1}}g{\mathcal{Q}}_{1}(h_{K},{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}K},{\mathcal{C}}{\mathcal{Q}}_{1}(\ldots ,{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-1}K},h_{\unicode[STIX]{x1D6F1}^{k+1}K})\cdots \,)))\,dx,\nonumber\end{eqnarray}$$
 $$\begin{eqnarray}\left.\frac{d}{dt}\right|_{t=0}V(\unicode[STIX]{x1D6F1}^{k}(1+tg))=\frac{(V(\unicode[STIX]{x1D6F1}^{k}B^{n})/V(B^{n}))^{1/n}}{2^{k}\unicode[STIX]{x1D714}_{n-1}^{k}}((\Box {\mathcal{C}})^{(k)}f_{\unicode[STIX]{x1D6F1}^{k}B^{n}})\int _{S^{n-1}}g\,dx.\end{eqnarray}$$
Proof. Let
 $L$
be a convex body of class
 $C_{+}^{2}.$
By [Reference Andrews1, Lemma 2-12], for
 $f\in C_{e}^{2}(S^{n-1})$
, we have
 $$\begin{eqnarray}\displaystyle \int _{S^{n-1}}f{\mathcal{Q}}_{1}(h_{L},g)\,dx=\int _{S^{n-1}}g{\mathcal{Q}}_{1}(h_{L},f)\,dx. & & \displaystyle\end{eqnarray}$$
Therefore, we obtain
 $$\begin{eqnarray}\left.\frac{d}{dt}\right|_{t=0}V(\unicode[STIX]{x1D6F1}^{k}(h_{K}+tg))=\int _{S^{n-1}}\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k}K}(g)f_{\unicode[STIX]{x1D6F1}^{k}K}\,dx.\end{eqnarray}$$
Note that
 ${\mathcal{C}}f_{\unicode[STIX]{x1D6F1}^{k}K}=2h_{\unicode[STIX]{x1D6F1}^{k+1}K}$
. Using (3.3),
 ${\mathcal{C}}$
is self-adjoint and (3.4), we calculate
 $$\begin{eqnarray}\displaystyle & & \displaystyle \int _{S^{n-1}}\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k}K}(g)f_{\unicode[STIX]{x1D6F1}^{k}K}\,dx\nonumber\\ \displaystyle & & \displaystyle \quad =(n-1)\int _{S^{n-1}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-1}K},\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k-1}K}(g))h_{\unicode[STIX]{x1D6F1}^{k+1}K}\,dx\nonumber\\ \displaystyle & & \displaystyle \quad =(n-1)\int _{S^{n-1}}\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k-1}K}(g){\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-1}K},h_{\unicode[STIX]{x1D6F1}^{k+1}K})\,dx\nonumber\\ \displaystyle & & \displaystyle \quad =\frac{(n-1)^{2}}{2}\int _{S^{n-1}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-2}K},\unicode[STIX]{x1D6FC}_{\unicode[STIX]{x1D6F1}^{k-2}K}(g)){\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-1}K},h_{\unicode[STIX]{x1D6F1}^{k+1}K})\,dx\nonumber\\ \displaystyle & & \displaystyle \quad =\frac{(n-1)^{k}}{2^{k-1}}\nonumber\\ \displaystyle & & \displaystyle \qquad \times \,\int _{S^{n-1}}g{\mathcal{Q}}_{1}(h_{K},{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}K},{\mathcal{C}}{\mathcal{Q}}_{1}(\ldots ,{\mathcal{C}}{\mathcal{Q}}_{1}(h_{\unicode[STIX]{x1D6F1}^{k-1}K},h_{\unicode[STIX]{x1D6F1}^{k+1}K})\cdots \,)))\,dx.\nonumber\end{eqnarray}$$
The second claim follows similarly. ◻
Lemma 3.5. The map
 ${\mathcal{Y}}_{m}:\tilde{U} \rightarrow C_{e}^{2}(S^{n-1})$
is smooth.
Proof. Lemmas 3.2 and 3.4 prove that the limit in (3.1) exists and it is linear in the second argument. We prove that
 $D{\mathcal{Y}}_{m}:\tilde{U} \times C_{e}^{2}(S^{n-1})\rightarrow C_{e}^{2}(S^{n-1})$
is continuous (the following argument also shows the continuity of
 ${\mathcal{Y}}_{m}$
). Suppose that
 $f_{i}\rightarrow _{C^{2}}f\in \tilde{U}$
and
 $g_{i}\rightarrow _{C^{2}}g\in C_{e}^{2}(S^{n-1}).$
There are convex bodies
 $\{K,K_{i}\}$
of class
 $C_{+}^{2}$
such that
 $1+f_{i}=h_{K_{i}}$
and
 $1+f=h_{K}.$
Since
 $h_{K_{i}}\rightarrow _{C^{2}}h_{K},$
we have
 $f_{K_{i}}\rightarrow _{C}f_{K}$
and so
 $$\begin{eqnarray}2h_{\unicode[STIX]{x1D6F1}K_{i}}={\mathcal{C}}f_{K_{i}}\rightarrow _{C^{2}}{\mathcal{C}}f_{K}=2h_{\unicode[STIX]{x1D6F1}K}.\end{eqnarray}$$
By induction,
 $h_{\unicode[STIX]{x1D6F1}^{l}h_{K_{i}}}\rightarrow _{C^{2}}h_{\unicode[STIX]{x1D6F1}^{l}h_{K}}$
for all
 $1\leqslant l\leqslant 2m+1.$
The continuity now follows from
 $D{\mathcal{Y}}_{m}(f_{i},g_{i})=d/dt|_{t=0}{\mathcal{X}}_{m}(h_{K_{i}}+tg_{i})$
and Lemmas 3.2 and 3.4.
Note that
 $D^{2}{\mathcal{X}}_{m}(h_{K},g_{1},g_{2})=d/dt|_{t=0}D{\mathcal{X}}_{m}(h_{K}+tg_{2},g_{1}).$
Since sufficient conditions for interchanging of differentiation and integration are satisfied, by (2.3) and (3.3), we conclude that
 $D^{2}{\mathcal{X}}_{m}$
exists and is continuous. The existence and continuity of higher derivatives follow by induction.◻
Remark 3.6. Our argument above shows that in fact for any
 $K$
of class
 $C_{+}^{2}$
, there is a
 $C^{2}$
-neighborhood of
 $h_{K}$
such that
 ${\mathcal{X}}_{m}$
is smooth.
The next lemma provides an interesting expression for
 $D{\mathcal{Y}}_{m}(0,\cdot )$
in terms of the spherical Radon transform.
Lemma 3.7. For any
 $g\in C_{e}^{2}(S^{n-1})$
, we have
 $$\begin{eqnarray}\displaystyle D{\mathcal{Y}}_{m}(0,g) & = & \displaystyle \biggl(\frac{V(\unicode[STIX]{x1D6F1}^{2m}B^{n})}{V(B^{n})}\biggr)^{1/n}\nonumber\\ \displaystyle & & \displaystyle \times \,\biggl(g-(n-1)^{2m}{\mathcal{R}}^{2m}g+\frac{(n-1)^{2m}-1}{n\unicode[STIX]{x1D714}_{n}}\int _{S^{n-1}}g\,dx\biggr).\nonumber\end{eqnarray}$$
Proof. Using Lemmas 3.2 and 3.4, we calculate
 $$\begin{eqnarray}\displaystyle \left.\frac{d}{dt}\right|_{t=0}{\mathcal{Y}}_{m}(tg) & = & \displaystyle -\frac{(V(\unicode[STIX]{x1D6F1}^{2m}B^{n})/V(B^{n}))^{1/n}}{2^{2m}\unicode[STIX]{x1D714}_{n-1}^{2m}}({\mathcal{C}}\Box )^{(2m)}g+\biggl(\frac{V(\unicode[STIX]{x1D6F1}^{2m}B^{n})}{V(B^{n})}\biggr)^{1/n}g\nonumber\\ \displaystyle & & \displaystyle +\,\frac{(V(\unicode[STIX]{x1D6F1}^{2m}B^{n})/V(B^{n}))^{2/n-1}}{2^{2m}\unicode[STIX]{x1D714}_{n-1}^{2m}}((\Box {\mathcal{C}})^{(2m)}f_{\unicode[STIX]{x1D6F1}^{2m}B^{n}})\frac{\int _{S^{n-1}}g\,dx}{n\unicode[STIX]{x1D714}_{n}}\nonumber\\ \displaystyle & & \displaystyle -\,\biggl(\frac{V(\unicode[STIX]{x1D6F1}^{2m}B^{n})}{V(B^{n})}\biggr)^{1/n}\frac{1}{n\unicode[STIX]{x1D714}_{n}}\int _{S^{n-1}}g\,dx.\end{eqnarray}$$
Since
 ${\mathcal{Y}}_{m}(t)=0$
for
 $t$
small enough,
 $$\begin{eqnarray}\displaystyle \left.\frac{d}{dt}\right|_{t=0}{\mathcal{Y}}_{m}(t) & = & \displaystyle 0\nonumber\\ \displaystyle & \Rightarrow & \displaystyle -({\mathcal{C}}\Box )^{(2m)}1+\biggl(\frac{V(\unicode[STIX]{x1D6F1}^{2m}B^{n})}{V(B^{n})}\biggr)^{1/n-1}((\Box {\mathcal{C}})^{(2m)}f_{\unicode[STIX]{x1D6F1}^{2m}B^{n}})=0.\nonumber\end{eqnarray}$$
Rearranging the terms yields
 $$\begin{eqnarray}\displaystyle \biggl(\frac{V(\unicode[STIX]{x1D6F1}^{2m}B^{n})}{V(B^{n})}\biggr)^{1/n-1}((\Box {\mathcal{C}})^{(2m)}f_{\unicode[STIX]{x1D6F1}^{2m}B^{n}})=(2\unicode[STIX]{x1D714}_{n-1}(n-1))^{2m}. & & \displaystyle \nonumber\end{eqnarray}$$
Substituting this last identity into (3.5) yields
 $$\begin{eqnarray}D{\mathcal{Y}}_{m}(0,g)=\biggl(\frac{V(\unicode[STIX]{x1D6F1}^{2m}B^{n})}{V(B^{n})}\biggr)^{1/n}\biggl(g-\frac{({\mathcal{C}}\Box )^{(2m)}g}{2^{2m}\unicode[STIX]{x1D714}_{n-1}^{2m}}+\frac{(n-1)^{2m}-1}{n\unicode[STIX]{x1D714}_{n}}\int _{S^{n-1}}g\,dx\biggr).\end{eqnarray}$$
For
 $g\in C^{2}(S^{n-1})$
,
 ${\mathcal{C}}\Box g=\Box {\mathcal{C}}g$
, so the identity (2.4) finishes the proof.◻
Lemma 3.8.
 $\operatorname{dim}\operatorname{Ker}D{\mathcal{Y}}_{m}(0,\cdot )=n(n+1)/2.$
Proof. Suppose that
 $g\in C_{e}^{2}(S^{n-1})$
. Recall from [Reference Groemer7, Lemma 3.4.7] that
 $$\begin{eqnarray}{\mathcal{R}}\unicode[STIX]{x1D70B}_{k}g=(-1)^{k/2}v_{k,n}\unicode[STIX]{x1D70B}_{k}g,\end{eqnarray}$$
where
 $$\begin{eqnarray}v_{k,n}=\left\{\begin{array}{@{}ll@{}}\displaystyle \frac{1\cdot 3\cdots (k-1)}{(n-1)(n+1)\cdots (n+k-3)}, & k\text{ even,}\\ \displaystyle 0, & k\text{ odd.}\end{array}\right.\end{eqnarray}$$
Since
 $D{\mathcal{Y}}_{m}(0,1)=0$
, we restrict our attention to the space of even functions with
 $\unicode[STIX]{x1D70B}_{0}g=(1/n\unicode[STIX]{x1D714}_{n})\int _{S^{n-1}}g\,dx=0.$
Note that
 $\Vert g\Vert _{2}^{2}=\sum _{k=1}^{\infty }\Vert \unicode[STIX]{x1D70B}_{2k}g\Vert _{2}^{2}$
and
 ${\mathcal{R}}\unicode[STIX]{x1D70B}_{k}g=\unicode[STIX]{x1D70B}_{k}{\mathcal{R}}g$
.Footnote
2
For all
 $j\in \mathbb{N},$
we have
 $$\begin{eqnarray}\displaystyle & \displaystyle \mathop{\sum }_{k=1}^{j}\unicode[STIX]{x1D70B}_{2k}g-(n-1)^{2m}{\mathcal{R}}^{2m}\biggl(\mathop{\sum }_{k=1}^{j}\unicode[STIX]{x1D70B}_{2k}g\biggr)=\mathop{\sum }_{k=1}^{j}(1-(n-1)^{2m}v_{2k,n}^{2m})\unicode[STIX]{x1D70B}_{2k}g, & \displaystyle \nonumber\\ \displaystyle & \displaystyle \Vert g-(n-1)^{2}{\mathcal{R}}^{2m}g\Vert _{2}^{2}=\mathop{\sum }_{k=1}^{\infty }(1-(n-1)^{2m}v_{2k,n}^{2m})^{2}\Vert \unicode[STIX]{x1D70B}_{2k}g\Vert _{2}^{2}. & \displaystyle \nonumber\end{eqnarray}$$
Recall that
 $v_{2,n}=1/(n-1).$
Hence,
 $g-(n-1)^{2m}{\mathcal{R}}^{2m}g=0$
if and only if
 $\unicode[STIX]{x1D70B}_{2k}g=0$
for all
 $k\neq 0,1.$
Consequently,
 $\operatorname{Ker}{\mathcal{Y}}_{m}(0,\cdot )={\mathcal{S}}^{0}\oplus {\mathcal{S}}^{2},$
which is of dimension
 $N(n,0)+N(n,2)=n(n+1)/2.$
◻
Lemma 3.9. Suppose that
 $m\geqslant 4.$
Given
 $h\in C_{e}^{2}(S^{n-1})$
with
 $\unicode[STIX]{x1D70B}_{k}h=0$
for
 $k=0,2$
, there exists a unique
 $g\in C_{e}^{2}(S^{n-1})$
with
 $\unicode[STIX]{x1D70B}_{k}g=0$
for
 $k=0,2$
such that
 $$\begin{eqnarray}g-(n-1)^{2m}{\mathcal{R}}^{2m}g=h.\end{eqnarray}$$
Proof. We develop
 $h$
into a series of spherical harmonics:
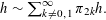 $h\sim \sum _{k\neq 0,1}^{\infty }\unicode[STIX]{x1D70B}_{2k}h.$
Since
 $L^{2}(S^{n-1})$
is a complete space and
 $\lim _{k\rightarrow \infty }1-(n-1)^{2m}v_{2k,n}^{2m}=1$
, the
 $L^{2}(S^{n-1})$
-Cauchy sequence
 $$\begin{eqnarray}\displaystyle \mathop{\biggl\{f_{l}:=\mathop{\sum }_{k\neq 0,1}^{l}\frac{1}{1-(n-1)^{2m}v_{2k,n}^{2m}}\unicode[STIX]{x1D70B}_{2k}h\biggr\}}\nolimits_{l} & & \displaystyle \nonumber\end{eqnarray}$$
converges in the
 $L^{2}(S^{n-1})$
-norm to a bounded even
 $f\in L^{2}(S^{n-1})\cap ({\mathcal{S}}^{0}\oplus {\mathcal{S}}^{2})^{\bot }$
with
 $$\begin{eqnarray}\unicode[STIX]{x1D70B}_{2k}f=\frac{1}{1-(n-1)^{2m}v_{2k,n}^{2m}}\unicode[STIX]{x1D70B}_{2k}h\end{eqnarray}$$
for
 $k\geqslant 2.$
In view of (2.5),
 ${\mathcal{R}}^{2m}f\in H_{e}^{m(n-2)}\subset H_{e}^{4(n-2)}\subset C^{2}(S^{n-1}).$
Define
 $$\begin{eqnarray}g:=h+(n-1)^{2m}{\mathcal{R}}^{2m}f.\end{eqnarray}$$
Note that
 $g\in C_{e}^{2}(S^{n-1})\cap ({\mathcal{S}}^{0}\oplus {\mathcal{S}}^{2})^{\bot }$
and, for
 $k\geqslant 2,$
 $$\begin{eqnarray}\unicode[STIX]{x1D70B}_{2k}g=\biggl(1+\frac{(n-1)^{2m}v_{2k,n}^{2m}}{1-(n-1)^{2m}v_{2k,n}^{2m}}\biggr)\unicode[STIX]{x1D70B}_{2k}h\Rightarrow \unicode[STIX]{x1D70B}_{2k}(g-(n-1)^{2m}{\mathcal{R}}^{2m}g)=\unicode[STIX]{x1D70B}_{2k}h.\end{eqnarray}$$
Since
 $h$
and
 $g-(n-1)^{2m}{\mathcal{R}}^{2m}g$
are
 $C^{2},$
 $g-(n-1)^{2m}{\mathcal{R}}^{2m}g=h.$
The proof of the uniqueness is elementary. ◻
4 Proof of the main result
In this section,
 $E$
always represents an ellipsoid and a vector
 $a\in \mathbb{R}^{n(n+3)/2}$
is written as
 $a=(a_{0},a_{1,1},\ldots ,a_{1,n},a_{2,1},\ldots ,a_{2,N(n,2)}).$
Let
 ${\mathcal{O}}_{1}$
be an open ball about the origin in
 $\mathbb{R}^{n(n+3)/2}$
such that for any
 $a\in {\mathcal{O}}_{1}$
:
-
(1)
$a_{0}+\sqrt{n}>0$
; -
(2)
$(a_{0}+\sqrt{n})^{2}/n+\sum _{i=1}^{N(n,2)}a_{2,i}Y_{2,i}>0$
; -
(3)
$s_{a}:=\sum _{i=1}^{n}a_{1,i}Y_{1,i}+((a_{0}+\sqrt{n})^{2}/n+\sum _{i=1}^{N(n,2)}a_{2,i}Y_{2,i})^{1/2}>0$
; -
(4)
$s_{a}$
is the support function of a convex body of class
$C_{+}^{2}$
.


The function
 $n/(a_{0}+\sqrt{n})^{2}(s_{a}-\sum _{i=1}^{n}a_{1,i}Y_{1,i})^{2}$
is the restriction of a positive-definite quadratic form to
 $S^{n-1}$
; therefore,
 $s_{a}$
is the support function of an ellipsoid with the center
 $(a_{1,1},\ldots ,a_{1,n})$
.
For an ellipsoid
 $E$
, there exists a vector
 $a\in \mathbb{R}^{n(n+3)/2}$
with
 $a_{0}>-\sqrt{n}$
such that
 $$\begin{eqnarray}h_{E}=\mathop{\sum }_{i=1}^{n}a_{1,i}Y_{1,i}+\biggl(\frac{(a_{0}+\sqrt{n})^{2}}{n}+\mathop{\sum }_{i=1}^{N(n,2)}a_{2,i}Y_{2,i}\biggr)^{1/2};\end{eqnarray}$$
see the proof of [Reference Groemer7, Theorem 5.8.1]Footnote 3 .
Define a map by
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D709}:{\mathcal{O}}_{1}\subset \mathbb{R}^{n(n+3)/2}\rightarrow C^{2}(S^{n-1}), & \displaystyle \nonumber\\ \displaystyle & \displaystyle \unicode[STIX]{x1D709}(a):=-1+\mathop{\sum }_{i=1}^{n}a_{1,i}Y_{1,i}+\biggl(\frac{(a_{0}+\sqrt{n})^{2}}{n}+\mathop{\sum }_{i=1}^{N(n,2)}a_{2,i}Y_{2,i}\biggr)^{1/2}. & \displaystyle \nonumber\end{eqnarray}$$
The following lemma shows that the space of ellipsoids near the unit ball can be parameterized by
 $\unicode[STIX]{x1D709}+1.$
Lemma 4.1. There exists
 $0<\unicode[STIX]{x1D6FF}<\frac{1}{2}$
with the following property. For any ellipsoid
 $E$
satisfying
 $\Vert h_{E}-1\Vert _{C}<\unicode[STIX]{x1D6FF}$
, there exists a unique
 $a\in {\mathcal{O}}_{1}$
such that
 $\unicode[STIX]{x1D709}(a)+1=h_{E}.$
Proof. Take an
 $a$
with
 $a_{0}>-\sqrt{n}$
such that (4.1) holds. The following relations show that if
 $\unicode[STIX]{x1D6FF}$
is small enough, then
 $a\in {\mathcal{O}}_{1}$
:
-
(1)
$\sum _{i}|a_{1,i}|=\sum _{i}|(h_{E}-h_{B^{n}},Y_{1,i})|\leqslant n\Vert h_{E}-1\Vert _{2}\leqslant n(n\unicode[STIX]{x1D714}_{n})^{1/2}\unicode[STIX]{x1D6FF}$
; -
(2)
$(n\unicode[STIX]{x1D714}_{n}((a_{0}+\sqrt{n})^{2}/n-1)^{2}+\sum _{i}a_{2,i}^{2})^{1/2}=\Vert h_{E-(a_{1,1},\ldots ,a_{1,n})}^{2}-1\Vert _{2}$
; -
(3)
$\Vert h_{E-(a_{1,1},\ldots ,a_{1,n})}^{2}-1\Vert _{2}\leqslant (n\unicode[STIX]{x1D714}_{n})^{1/2}\Vert h_{E-(a_{1,1},\ldots ,a_{1,n})}^{2}-1\Vert _{C}\leqslant c(\sum _{i}|a_{1,i}|+\unicode[STIX]{x1D6FF})$
for some positive constant
$c$
independent of
$E.$


The proof of the uniqueness claim is elementary. ◻
Lemma 4.2. The following statements hold.
-
(1) There exists an origin-centered open ball
${\mathcal{O}}_{2}\subset {\mathcal{O}}_{1}$
such that for any open set
${\mathcal{O}}\subset {\mathcal{O}}_{2}$
,
$(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{1}+\unicode[STIX]{x1D70B}_{2})(\unicode[STIX]{x1D709}({\mathcal{O}}))$
is an open set in
${\mathcal{S}}^{0}\oplus {\mathcal{S}}^{1}\oplus {\mathcal{S}}^{2}\equiv \mathbb{R}^{n(n+3)/2}.$
-
(2) Put
$S:=\{a\in \mathbb{R}^{n(n+3)/2};a_{1,i}=0,i=1,\ldots ,n\}$
. There exists an origin-centered open ball
${\mathcal{O}}_{2}\subset {\mathcal{O}}_{1}\cap S$
such that for any open set
${\mathcal{O}}\subset {\mathcal{O}}_{2}$
, the set
$(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{2})(\unicode[STIX]{x1D709}({\mathcal{O}}))$
is open in
${\mathcal{S}}^{0}\oplus {\mathcal{S}}^{2}\equiv \mathbb{R}^{n(n+1)/2}.$


Proof. We only prove the first claim. The map
 $\unicode[STIX]{x1D709}$
is smooth and its derivative at the origin is given by
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}\unicode[STIX]{x2202}\unicode[STIX]{x1D709}(0):\mathbb{R}^{n(n+3)/2}\rightarrow C^{2}(S^{n-1}),\\ \displaystyle \unicode[STIX]{x2202}\unicode[STIX]{x1D709}(0)h=\sqrt{\unicode[STIX]{x1D714}_{n}}h_{0,1}Y_{0,1}+\mathop{\sum }_{i=1}^{n}h_{1,i}Y_{1,i}+\frac{1}{2}\mathop{\sum }_{i=1}^{N(n,2)}h_{2,i}Y_{2,i}.\end{array}\right.\end{eqnarray}$$
Let
 $\{\unicode[STIX]{x1D706}_{0},\unicode[STIX]{x1D706}_{1},\ldots ,\unicode[STIX]{x1D706}_{n(n+3)/2-1}\}$
be the coordinates of
 $(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{1}+\unicode[STIX]{x1D70B}_{2})\unicode[STIX]{x1D709}(a)$
with respect to the basis
 $\{Y_{k,l};l=1,\ldots ,N(n,k),k=0,1,2\}$
of
 ${\mathcal{S}}^{0}\oplus {\mathcal{S}}^{1}\oplus {\mathcal{S}}^{2}$
. By (4.2), we obtain
 $$\begin{eqnarray}\unicode[STIX]{x2202}\unicode[STIX]{x1D706}(0)=\operatorname{diag}(\sqrt{\unicode[STIX]{x1D714}_{n}},\underbrace{1,\ldots ,1}_{n\text{ times}},{\textstyle \frac{1}{2}},\ldots ,{\textstyle \frac{1}{2}}).\end{eqnarray}$$
Hence, the inverse function theorem implies that there exists an origin-centered open ball
 ${\mathcal{O}}_{2}\subset {\mathcal{O}}_{1}$
such that
 $\unicode[STIX]{x1D706}:{\mathcal{O}}_{2}\rightarrow \unicode[STIX]{x1D706}({\mathcal{O}}_{2})$
is a smooth diffeomorphism.◻
The proof of the next theorem was inspired by the work of Simon [Reference Simon20].
Theorem 4.3. Suppose that
 $m\geqslant 4.$
There exists
 $\unicode[STIX]{x1D700}_{m}>0$
such that if
 $h_{K}$
satisfies
 ${\mathcal{X}}_{m}(h_{K})=0$
and
 $\Vert h_{\unicode[STIX]{x1D719}K}-1\Vert _{C^{2}}\leqslant \unicode[STIX]{x1D700}_{m}$
for some
 $\unicode[STIX]{x1D719}\in \operatorname{Gl}_{n},$
then
 $K$
is an origin-centered ellipsoid. In particular, if
 $\unicode[STIX]{x1D6F1}^{2}K=cK$
for some positive constant
 $c$
and
 $\Vert h_{\unicode[STIX]{x1D719}K}-1\Vert _{C^{2}}\leqslant \unicode[STIX]{x1D700}_{4}$
for some
 $\unicode[STIX]{x1D719}\in \operatorname{Gl}_{n}$
, then
 $K$
is an origin-centered ellipsoid.
Proof. Consider the map
 $$\begin{eqnarray}\displaystyle & \displaystyle {\mathcal{N}}:\tilde{U} \subset C_{e}^{2}(S^{n-1})\rightarrow C_{e}^{2}(S^{n-1}), & \displaystyle \nonumber\\ \displaystyle & \displaystyle f\mapsto {\mathcal{Y}}_{m}(f)+(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{2})f,\qquad {\mathcal{N}}(0)=0. & \displaystyle \nonumber\end{eqnarray}$$
-
∙ By Lemma 3.5,
${\mathcal{N}}$
is smooth. -
∙ By Lemma 3.9, the linear map
is an isomorphism.
$$\begin{eqnarray}\displaystyle D{\mathcal{N}}(0,\cdot ):C_{e}^{2}(S^{n-1})\rightarrow C_{e}^{2}(S^{n-1}),\qquad f\mapsto D{\mathcal{Y}}_{m}(0,f)+(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{2})f & & \displaystyle \nonumber\end{eqnarray}$$


By the inverse function theorem (see [Reference Hamilton8, Theorem 5.2.3 and Corollary 5.3.4]), we can find open neighborhoods
 $U,W$
of
 $0$
in
 $C_{e}^{2}(S^{n-1})$
such that
 ${\mathcal{N}}:U\subset \tilde{U} \rightarrow W$
is a smooth diffeomorphism. Put
 $M={\mathcal{N}}^{-1}(W\cap \operatorname{Ker}D{\mathcal{Y}}_{m}(0,\cdot ))$
. A key observation is that
 $M$
contains all solutions of
 ${\mathcal{Y}}_{m}(\cdot )=0$
in
 $U;$
that is,
 $$\begin{eqnarray}\displaystyle f\in U\quad \text{and}\quad {\mathcal{Y}}_{m}(f)=0\Rightarrow {\mathcal{N}}^{-1}((\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{2})(f))=f\in M. & & \displaystyle\end{eqnarray}$$
Define
 $W^{\prime }:=\{(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{2})(h_{E}-1);h_{E}-1\in U,E=-E\}.$
By (4.3), we have
 ${\mathcal{N}}^{-1}(W^{\prime })=\{h_{E}-1;h_{E}-1\in U,E=-E\}.$
Also, due to Lemmas 4.1 and 4.2, if
 $U$
is small enough, then
 $W^{\prime }$
is open in
 $W\cap \operatorname{Ker}D{\mathcal{Y}}_{m}(0,\cdot ).$
Let us define the open set
 $W_{1}:=\{f\in W;(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{2})f\in W^{\prime }\}.$
From the definition of
 $W^{\prime }$
, it follows that
 $W^{\prime }=W_{1}\cap \operatorname{Ker}D{\mathcal{Y}}_{m}(0,\cdot );$
therefore, we have
 $$\begin{eqnarray}{\mathcal{N}}^{-1}(W^{\prime })={\mathcal{N}}^{-1}(W_{1}\cap W\cap \operatorname{Ker}D{\mathcal{Y}}_{m}(0,\cdot ))={\mathcal{N}}^{-1}(W_{1})\cap M.\end{eqnarray}$$
Note that
 ${\mathcal{N}}^{-1}(W_{1})\subset U$
contains an open neighborhood of
 $0$
in
 $C_{e}^{2}(S^{n-1}).$
Thus, there exists
 $\unicode[STIX]{x1D700}_{m}>0$
such that if
 ${\mathcal{Y}}_{m}(f)=0$
and
 $\Vert f-1\Vert _{C^{2}}\leqslant \unicode[STIX]{x1D700}_{m}$
, then
 $$\begin{eqnarray}f\in M\cap {\mathcal{N}}^{-1}(W_{1})=\{h_{E}-1;h_{E}-1\in U,E=-E\}.\end{eqnarray}$$
Consequently, in a
 $C_{e}^{2}(S^{n-1})$
-neighborhood of
 $1$
the only solutions of
 ${\mathcal{Y}}_{m}(\cdot -1)=0$
are support functions of origin-centered ellipsoids.
To prove the last statement, observe that if
 $\unicode[STIX]{x1D6F1}^{2}K=cK$
for some positive constant
 $c$
, then
 $\unicode[STIX]{x1D6F1}^{8}\unicode[STIX]{x1D719}K=c^{\prime }\unicode[STIX]{x1D719}K$
for some positive constant
 $c^{\prime }.$
So,
 ${\mathcal{X}}_{4}(h_{\unicode[STIX]{x1D719}K})={\mathcal{Y}}_{4}(h_{\unicode[STIX]{x1D719}K}-1)=0.$
Hence,
 $K$
must be an origin-centered ellipsoid.◻
Remark 4.4. Here
 $c_{i}$
are positive constants depending only on
 $n.$
Suppose that
 $K$
has a positive continuous curvature function
 $f_{K}$
. The inequality (2.3) implies that
 $$\begin{eqnarray}\displaystyle \Vert {\mathcal{C}}f_{K}-{\mathcal{C}}1\Vert _{C^{2}} & = & \displaystyle \Vert {\mathcal{C}}(f_{K}-1)\Vert _{C^{2}}\leqslant c_{1}\Vert f_{K}-1\Vert _{C}\nonumber\\ \displaystyle & \Rightarrow & \displaystyle \Vert h_{\unicode[STIX]{x1D6F1}K}-h_{\unicode[STIX]{x1D6F1}B^{n}}\Vert _{C^{2}}\leqslant c_{2}\Vert f_{K}-1\Vert _{C}.\nonumber\end{eqnarray}$$
Therefore, if
 $\Vert f_{K}-1\Vert _{C}$
is small enough, then
 $$\begin{eqnarray}\Vert f_{\unicode[STIX]{x1D6F1}K}-f_{\unicode[STIX]{x1D6F1}B^{n}}\Vert _{C}\leqslant c_{3}\Vert f_{K}-1\Vert _{C}\Rightarrow \Vert h_{\unicode[STIX]{x1D6F1}^{2}K}-h_{\unicode[STIX]{x1D6F1}^{2}B^{n}}\Vert _{C^{2}}\leqslant c_{4}\Vert f_{K}-1\Vert _{C}.\end{eqnarray}$$
In particular, for any solution of
 $\unicode[STIX]{x1D6F1}^{2}K=cK$
, we have
 $$\begin{eqnarray}\Vert h_{\unicode[STIX]{x1D713}K}-1\Vert _{C^{2}}\leqslant c_{5}\Vert f_{K}-1\Vert _{C},\end{eqnarray}$$
where
 $\unicode[STIX]{x1D713}=(c/\unicode[STIX]{x1D714}_{n-1}^{n})\operatorname{I}_{n\times n}$
. Therefore, Theorem 4.3 (or the main result of the paper) holds under the assumption that
 $\Vert f_{\unicode[STIX]{x1D719}K}-1\Vert _{C}$
is small enough.
5 Equality cases of (1.1)
For a body
 $K\in \text{K}^{n}$
of class
 $C_{+}^{2}$
, define
 $$\begin{eqnarray}{\mathcal{L}}h_{K}:=\Box h_{K}-(n-1)^{2}{\mathcal{R}}^{2}\Box h_{K}+\frac{(n-2)(n-1)}{\unicode[STIX]{x1D714}_{n}}\int _{S^{n-1}}h_{K}\,dx.\end{eqnarray}$$
We will show that
 $$\begin{eqnarray}\displaystyle & & \displaystyle W_{n-2}(\unicode[STIX]{x1D6F1}_{n-2}K)-\frac{n(n-2)\unicode[STIX]{x1D714}_{n-1}^{2}}{(n-1)^{2}\unicode[STIX]{x1D714}_{n}}W_{n-1}^{2}(K)-\frac{\unicode[STIX]{x1D714}_{n-1}^{2}}{(n-1)^{2}}W_{n-2}(K)\nonumber\\ \displaystyle & & \displaystyle \quad =-c_{n}\int _{S^{n-1}}h_{K}{\mathcal{L}}h_{K}\,dx\nonumber\\ \displaystyle & & \displaystyle \quad =c_{n}\mathop{\sum }_{k=3}^{\infty }(k-1)(n+k-1)(1-v_{k,n}^{2}(n-1)^{2})\Vert \unicode[STIX]{x1D70B}_{k}h_{K}\Vert _{2}^{2}.\nonumber\end{eqnarray}$$
Here
 $c_{n}$
is some positive constant independent of
 $K.$
By [Reference Goodey and Groemer5, p. 1109], for any convex body
 $L$
with
 $h_{L}\in C^{2}(S^{n-1})$
, we have
 $$\begin{eqnarray}\displaystyle W_{n-2}(L):=V(B^{n},\ldots ,B^{n},L,L)=\frac{1}{n(n-1)}\int _{S^{n-1}}h_{L}\Box h_{L}\,dx. & & \displaystyle\end{eqnarray}$$
In addition, for a convex body
 $L$
of class
 $C_{+}^{2}$
, we have
 $$\begin{eqnarray}\displaystyle h_{\unicode[STIX]{x1D6F1}_{n-2}L}(u) & := & \displaystyle h_{\unicode[STIX]{x1D6F1}(B^{n},\ldots ,B^{n},L)}(u)\nonumber\\ \displaystyle & = & \displaystyle \frac{1}{2}\int _{S^{n-1}}|u\cdot x|\,dS(B^{n},\ldots ,B^{n},L)\nonumber\\ \displaystyle & = & \displaystyle \frac{1}{2(n-1)}{\mathcal{C}}\Box h_{L}(u).\end{eqnarray}$$
Since
 ${\mathcal{C}}\Box h_{K}\in C^{2}(S^{n-1}),$
putting (5.1) and (5.2) together yields
 $$\begin{eqnarray}W_{n-2}(\unicode[STIX]{x1D6F1}_{n-2}K)=\frac{1}{4n(n-1)^{3}}\int _{S^{n-1}}{\mathcal{C}}\Box h_{K}\Box {\mathcal{C}}\Box h_{K}\,dx.\end{eqnarray}$$
We use that both
 ${\mathcal{C}}$
and
 $\Box$
are self-adjoint to obtain
 $$\begin{eqnarray}\displaystyle W_{n-2}(\unicode[STIX]{x1D6F1}_{n-2}K) & = & \displaystyle \frac{1}{4n(n-1)^{3}}\int _{S^{n-1}}{\mathcal{C}}\Box h_{K}\Box {\mathcal{C}}\Box h_{K}\,dx\nonumber\\ \displaystyle & = & \displaystyle \frac{1}{4n(n-1)^{3}}\int _{S^{n-1}}h_{K}\Box {\mathcal{C}}\Box {\mathcal{C}}\Box h_{K}\,dx.\nonumber\end{eqnarray}$$
Thus, by the identity (2.4), we arrive at the formula
 $$\begin{eqnarray}\displaystyle W_{n-2}(\unicode[STIX]{x1D6F1}_{n-2}K)=\frac{\unicode[STIX]{x1D714}_{n-1}^{2}}{n(n-1)}\int _{S^{n-1}}h_{K}{\mathcal{R}}^{2}\Box h_{K}\,dx. & & \displaystyle\end{eqnarray}$$
We also need
 $$\begin{eqnarray}\displaystyle W_{n-1}(K):=V_{1}(B^{n},K)=\frac{1}{n}\int _{S^{n-1}}h_{K}\,dx. & & \displaystyle\end{eqnarray}$$
Combining (5.1), (5.3) and (5.4) all together gives
 $$\begin{eqnarray}\displaystyle & & \displaystyle W_{n-2}(\unicode[STIX]{x1D6F1}_{n-2}K)-\frac{n(n-2)\unicode[STIX]{x1D714}_{n-1}^{2}}{(n-1)^{2}\unicode[STIX]{x1D714}_{n}}W_{n-1}^{2}(K)-\frac{\unicode[STIX]{x1D714}_{n-1}^{2}}{(n-1)^{2}}W_{n-2}(K)\nonumber\\ \displaystyle & & \displaystyle \quad =\frac{\unicode[STIX]{x1D714}_{n-1}^{2}}{n(n-1)}\int _{S^{n-1}}h_{K}{\mathcal{R}}^{2}\Box h_{K}\,dx\nonumber\\ \displaystyle & & \displaystyle \qquad -\,\frac{(n-2)\unicode[STIX]{x1D714}_{n-1}^{2}}{n(n-1)^{2}\unicode[STIX]{x1D714}_{n}}\biggl(\int _{S^{n-1}}h_{K}\,dx\biggr)^{2}-\frac{\unicode[STIX]{x1D714}_{n-1}^{2}}{n(n-1)^{3}}\int _{S^{n-1}}h_{K}\Box h_{K}\,dx\nonumber\\ \displaystyle & & \displaystyle \quad =\frac{\unicode[STIX]{x1D714}_{n-1}^{2}}{n(n-1)^{3}}\int _{S^{n-1}}h_{K}\bigg((n-1)^{2}{\mathcal{R}}^{2}\Box h_{K}\nonumber\\ \displaystyle & & \displaystyle \qquad +\,\frac{(2-n)(n-1)}{\unicode[STIX]{x1D714}_{n}}\int _{S^{n-1}}h_{K}\,dx-\Box h_{K}\bigg)\,dx\nonumber\\ \displaystyle & & \displaystyle \quad =-c_{n}\int _{S^{n-1}}h_{K}{\mathcal{L}}h_{K}\,dx.\nonumber\end{eqnarray}$$
Note that
 ${\mathcal{L}}1=0$
. Assume that
 $Y_{k}$
is a spherical harmonic of degree
 $k\geqslant 1$
. Since
 $\int _{S^{n-1}}Y_{k}\,dx=0,$
from
 $\Box Y_{k}=-(k-1)(n+k-1)Y_{k}$
and
 ${\mathcal{R}}Y_{k}=(-1)^{k/2}v_{k,n}Y_{k}$
it follows that
 $$\begin{eqnarray}{\mathcal{L}}Y_{k}=-(k-1)(n+k-1)(1-(n-1)^{2}v_{k,n}^{2})Y_{k}.\end{eqnarray}$$
Therefore, since
 ${\mathcal{L}}$
is linear and self-adjoint, if
 $K$
is of class
 $C_{+}^{2}$
, then
 $$\begin{eqnarray}\displaystyle (h_{K},{\mathcal{L}}h_{K}) & = & \displaystyle -\int _{S^{n-1}}\mathop{\sum }_{k=0}^{\infty }\unicode[STIX]{x1D70B}_{k}h_{K}\nonumber\\ \displaystyle & & \displaystyle \times \,\biggl(\mathop{\sum }_{k=3}^{\infty }(k-1)(n+k-1)(1-v_{k,n}^{2}(n-1)^{2})\unicode[STIX]{x1D70B}_{k}h_{K}\biggr)\,dx\nonumber\\ \displaystyle & = & \displaystyle -\mathop{\sum }_{k=3}^{\infty }(k-1)(n+k-1)(1-v_{k,n}^{2}(n-1)^{2})\Vert \unicode[STIX]{x1D70B}_{k}h_{K}\Vert _{2}^{2}\nonumber\end{eqnarray}$$
and consequently for any
 $k\geqslant 3$
we obtain
 $$\begin{eqnarray}\displaystyle & & \displaystyle W_{n-2}(\unicode[STIX]{x1D6F1}_{n-2}K)-\frac{n(n-2)\unicode[STIX]{x1D714}_{n-1}^{2}}{(n-1)^{2}\unicode[STIX]{x1D714}_{n}}W_{n-1}^{2}(K)-\frac{\unicode[STIX]{x1D714}_{n-1}^{2}}{(n-1)^{2}}W_{n-2}(K)\nonumber\\ \displaystyle & & \displaystyle \quad \geqslant c_{n,k}\Vert \unicode[STIX]{x1D70B}_{k}h_{K}\Vert _{2}^{2}\geqslant 0.\nonumber\end{eqnarray}$$
The class of
 $C_{+}^{\infty }$
convex bodies is dense in
 $\text{K}^{n}$
. Thus, a standard approximation shows that this last inequality holds for all convex bodies. Thus, the left-hand side is zero precisely when the support function has the form
 $$\begin{eqnarray}h_{K}=(\unicode[STIX]{x1D70B}_{0}+\unicode[STIX]{x1D70B}_{1}+\unicode[STIX]{x1D70B}_{2})h_{K}.\end{eqnarray}$$
Note that, indeed, we have proved that
 $$\begin{eqnarray}\left.\frac{d^{2}}{dt^{2}}\right|_{t=0}{\mathcal{P}}(1+th_{K})=\left.\frac{d^{2}}{dt^{2}}\right|_{t=0}\frac{V(\unicode[STIX]{x1D6F1}(1+th_{K}))}{V(1+th_{K})^{n-1}}=-c_{n}^{\prime }\int _{S^{n-1}}h_{K}{\mathcal{L}}h_{K}\,dx\geqslant 0\end{eqnarray}$$
and
 $\operatorname{Ker}{\mathcal{L}}={\mathcal{S}}^{0}\oplus {\mathcal{S}}^{1}\oplus {\mathcal{S}}^{2}.$
The
 $\operatorname{Ker}{\mathcal{L}}$
reflects the symmetries (the affine invariance) that
 ${\mathcal{P}}$
enjoys;
 ${\mathcal{S}}^{0}$
,
 ${\mathcal{S}}^{1}$
and
 ${\mathcal{S}}^{2}$
are present in
 $\operatorname{Ker}{\mathcal{L}}$
, respectively, because
 ${\mathcal{P}}$
is scaling-invariant, translation-invariant and
 $\operatorname{Sl}_{n}$
-invariant.
Acknowledgements
The work of the author was supported by the Austrian Science Fund (FWF) Project M1716-N25 and the European Research Council (ERC) Project 306445. I would like to thank C. Saroglou and A. Zvavitch for a discussion related to §5. I would also like to thank immensely the referee for the very constructive suggestions that have led to a much better presentation of the original manuscript.



