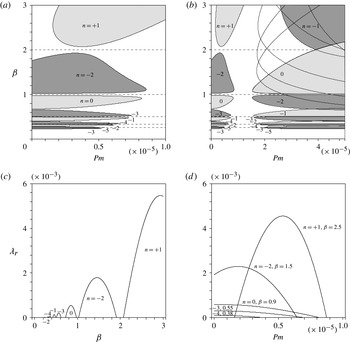
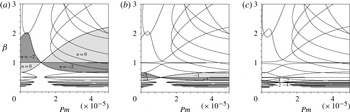
1. Introduction
The interaction of rotational flows and magnetic fields is of fundamental importance for many geo- and astrophysical problems (Rüdiger, Kitchatinov & Hollerbach Reference Rüdiger, Kitchatinov and Hollerbach2013). On one hand, rotating cosmic bodies, such as planets, stars and galaxies, are known to generate magnetic fields by means of the hydromagnetic dynamo effect. Magnetic fields, in turn, can destabilize rotating flows that would otherwise be hydrodynamically stable. This effect is particularly important for accretion disks in active galactic nuclei, dwarf novae and protoplanetary systems, where it allows the tremendous enhancement of outward-directed angular momentum transport that is necessary to explain the typical mass flow rates onto the respective central objects. Although this magnetorotational instability (MRI), as we call it now, had been discovered in 1959 by Velikhov (Reference Velikhov1959) and then confirmed in 1960 by Chandrasekhar (Reference Chandrasekhar1960), it was left to Balbus & Hawley (Reference Balbus and Hawley1991) to point out its relevance for astrophysical accretion processes. Their seminal paper has inspired many investigations related to the action of MRI in active galactic nuclei (Krolik Reference Krolik1998), X-ray binaries (Done, Gierlinski & Kubota Reference Done, Gierlinski and Kubota2007), protoplanetary disks (Armitage Reference Armitage2011), stars (Kagan & Wheeler Reference Kagan and Wheeler2014), and even planetary cores (Petitdemange, Dormy & Balbus Reference Petitdemange, Dormy and Balbus2008).
An interesting question concerns the non-trivial interplay of the hydromagnetic dynamo effect and magnetically triggered flow instabilities. For a long time, dynamo research had been focused on how a prescribed flow can produce a magnetic field and, to a lesser extent, on how the self-excitation process saturates when the magnetic field becomes strong enough to act against the source of its own generation. Similarly, most of the early MRI studies have assumed some prescribed magnetic field, e.g. a purely axial or a purely azimuthal field, to assess its capability for triggering instabilities and turbulent angular momentum transport in the flow. Nowadays, however, we witness an increasing interest in treating the dynamo effect and instabilities in magnetized flows in a more self-consistent manner. Combining both processes one can look for the existence of ‘self-creating dynamos’ (Fuchs, Rädler & Rheinhardt Reference Fuchs, Rädler and Rheinhardt1999), i.e. dynamos whose magnetic field triggers, at least partly, the flow structures that are responsible for its self-excitation.
A paradigm of such an essentially nonlinear dynamo problem is the case of an accretion disk without any externally applied axial magnetic field. In this case the magnetic field can only be produced in the disk itself, very likely by a periodic MRI dynamo process (Herault et al.
Reference Herault, Rincon, Cossu, Lesur, Ogilvie and Longaretti2011) or some sort of an
 ${\it\alpha}{-}{\rm\Omega}$
dynamo (Brandenburg et al.
Reference Brandenburg, Nordlund, Stein and Torkelsson1995), the
 ${\it\alpha}$
part of which relies on the turbulent flow structure arising due to the MRI. Such a closed loop of magnetic field self-excitation and MRI has attracted much attention in the past, though with many unsolved questions concerning numerical convergence (Fromang & Papaloizou Reference Fromang and Papaloizou2007), the influence of disk stratification (Shi, Krolik & Hirose Reference Shi, Krolik and Hirose2010), and the role of boundary conditions for the magnetic field (Käpylä & Korpi Reference Käpylä and Korpi2011).
In problems of that kind, a key role is played by the so-called magnetic Prandtl number
 $\mathit{Pm}={\it\nu}/{\it\eta}$
, i.e. the ratio of the viscosity
 ${\it\nu}$
of the fluid to its magnetic diffusivity
 ${\it\eta}=({\it\mu}_{0}{\it\sigma})^{-1}$
(with
 ${\it\mu}_{0}$
denoting the magnetic permeability of free space and
 ${\it\sigma}$
the conductivity). For the case of an axially applied field, a first systematic study of the
 $\mathit{Pm}$
-dependence of the growth rate and the angular momentum transport coefficient was carried out by Lesur & Longaretti (Reference Lesur and Longaretti2007). The closed-loop MRI-dynamo process, which seems to work well for
 $\mathit{Pm}=O(1)$
(Herault et al.
Reference Herault, Rincon, Cossu, Lesur, Ogilvie and Longaretti2011), is much more intricate for small values of
 $\mathit{Pm}$
, as they are typical for the outer parts of accretion disks around black holes and for protoplanetary disks. At least for stratified disks, Oishi & Mac Low (Reference Oishi and Mac Low2011) have recently claimed that they have found evidence for a critical magnetic Reynolds number
 $\mathit{Rm}_{crit}$
in the order of 3000 that is mainly independent of
 $\mathit{Pm}$
. A somewhat higher value of
 $\mathit{Rm}_{crit}$
had been found earlier by Fleming, Stone & Hawley (Reference Fleming, Stone and Hawley2000) when considering resistivity while still neglecting viscous effects.
Another paradigm of the interplay of self-excitation and magnetically triggered instabilities is the so-called Tayler–Spruit dynamo as proposed by Spruit (Reference Spruit2002). In this particular (and controversial) model of stellar magnetic field generation, the
 ${\rm\Omega}$
part of the dynamo process (to produce toroidal field from poloidal field) is played, as usual, by the differential rotation, while the
 ${\it\alpha}$
part (to produce poloidal from toroidal field) is taken by the flow structure arising from the kink-type Tayler instability (Tayler Reference Tayler1973) that sets in when the toroidal field acquires a critical strength to overcome stable stratification.
At small values of
 $\mathit{Pm}$
, both dynamo- and MRI-related problems are very hard to treat numerically. This has to do with the fact that both phenomena rely on induction effects which require some finite magnetic Reynolds number. This number is the ratio of magnetic field production by the velocity to magnetic field dissipation due to Joule heating. For a fluid flow with typical size
 $L$
and typical velocity
 $V$
it can be expressed as
 $\mathit{Rm}={\it\mu}_{0}{\it\sigma}LV$
. The numerical difficulty for small-
 $\mathit{Pm}$
problems arises then from the fact that the hydrodynamic Reynolds number, i.e.
 $\mathit{Re}=Pm^{-1}Rm$
, becomes very large, so that extremely fine structures have to be resolved. Furthermore, for MRI problems it is additionally necessary that the magnetic Lundquist number, which is simply a magnetic Reynolds number based on the Alfvén velocity
 $v_{A}$
, i.e.
 $S={\it\mu}_{0}{\it\sigma}Lv_{A}$
, must also be of the order of 1.
A complementary way to study the interaction of rotating flows and magnetic field at small
 $\mathit{Pm}$
and comparably large
 $\mathit{Rm}$
is by means of liquid-metal experiments. As for the dynamo problem, quite a number of experiments have been carried out (Stefani, Gailitis & Gerbeth Reference Stefani, Gailitis and Gerbeth2008). Up to the present, magnetic field self-excitation has been attained in the liquid-sodium experiments in Riga (Gailitis et al.
Reference Gailitis, Lielausis, Dement’ev, Platacis, Cifersons, Gerbeth, Gundrum, Stefani, Christen, Hänel and Will2000), Karlsruhe (Müller & Stieglitz Reference Müller and Stieglitz2000), and Cadarache (Monchaux et al.
Reference Monchaux, Berhanu, Bourgoin, Moulin, Odier, Pinton, Volk, Fauve, Mordant, Petrelis, Chiffaudel, Daviaud, Dubrulle, Gasquet, Mari and Ravelet2007). Closely related to these dynamo experiments, some groups have also attempted to explore the standard version of MRI (SMRI), which corresponds to the case that a purely vertical magnetic field is being applied to the flow (Sisan et al.
Reference Sisan, Mujica, Tillotson, Huang, Dorland, Hassam, Antonsen and Lathrop2004; Nornberg et al.
Reference Nornberg, Ji, Schartman and Roach2010). Recently, the current-driven, kink-type Tayler instability was identified in a liquid-metal experiment (Seilmayer et al.
Reference Seilmayer, Stefani, Gundrum, Weier, Gerbeth, Gellert and Rüdiger2012), the findings of which were numerically confirmed in the framework of an integro-differential equation approach by Weber et al. (Reference Weber, Galindo, Stefani, Weier and Wondrak2013).
In view of the peculiarities in doing numerics, and experiments, on the standard version of MRI at low
 $\mathit{Pm}$
, it came as a surprise when Hollerbach & Rüdiger (Reference Hollerbach and Rüdiger2005) showed that the simultaneous application of an axial and an azimuthal magnetic field can change completely the parameter scaling for the onset of MRI. For
 $B_{{\it\phi}}/B_{z}\sim 1$
, the helical MRI (HMRI), as we call it now, was shown to occur even in the inductionless limit (Kirillov & Stefani Reference Kirillov and Stefani2011; Priede Reference Priede2011),
 $\mathit{Pm}=0$
, and to be governed by the Reynolds number
 $\mathit{Re}=\mathit{Rm}\mathit{Pm}^{-1}$
and the Hartmann number
 $\mathit{Ha}=S\mathit{Pm}^{-1/2}$
, quite in contrast to standard MRI (SMRI) that was known to be governed by
 $\mathit{Rm}$
and
 $S$
(Ji, Goodman & Kageyama Reference Ji, Goodman and Kageyama2001).
Very soon, however, the enthusiasm about this new inductionless version of MRI cooled down when Liu et al. (Reference Liu, Goodman, Herron and Ji2006) showed that HMRI would only occur for relatively steep rotation profiles, see also Ji & Balbus (Reference Ji and Balbus2013). Using a short-wavelength approximation, they were able to identify a minimum steepness of the rotation profile
 ${\rm\Omega}(R)$
, expressed by the Rossby number
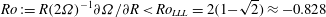 $\mathit{Ro}:=R(2{\rm\Omega})^{-1}\partial {\rm\Omega}/\partial R<\mathit{Ro}_{LLL}=2(1-\sqrt{2})\approx -0.828$
. This limit, which we will call the lower Liu limit (LLL) in the following, implies that for
 $B_{{\it\phi}}(R)\propto 1/R$
the inductionless HMRI does not extend to the Keplerian case, characterized by
 $\mathit{Ro}_{Kep}=-\frac{3}{4}$
. Interestingly, Liu et al. (Reference Liu, Goodman, Herron and Ji2006) found a second threshold of the Rossby number also, which we call the upper Liu limit (ULL), at
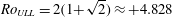 $\mathit{Ro}_{ULL}=2(1+\sqrt{2})\approx +4.828$
. This second limit, which predicts a magnetic destabilization of extremely stable flows with strongly increasing angular frequency, has received almost no attention to date, but will play an important role in the present paper.
Regarding the general relation between HMRI and SMRI, two apparently contradictory observations have to be mentioned. On one hand, the numerical results of Hollerbach & Rüdiger (Reference Hollerbach and Rüdiger2005) had clearly demonstrated a continuous and monotonic transition between HMRI and SMRI. On the other hand, HMRI was identified by Liu et al. (Reference Liu, Goodman, Herron and Ji2006) as a weakly destabilized inertial oscillation, quite in contrast to the SMRI which represents a destabilized slow magneto-Coriolis wave. Only recently, this paradox was resolved by showing that the transition involves a spectral exceptional point at which the inertial wave branch coalesces with the branch of the slow magneto-Coriolis wave (Kirillov & Stefani Reference Kirillov and Stefani2010).
The significance of the LLL, together with a variety of further predicted parameter dependences, was experimentally confirmed in the PROMISE facility, a Taylor–Couette cell working with a low-
 $\mathit{Pm}$
liquid metal (Stefani et al.
Reference Stefani, Gundrum, Gerbeth, Rüdiger, Schultz, Szklarski and Hollerbach2006, Reference Stefani, Gundrum, Gerbeth, Rüdiger, Szklarski and Hollerbach2007, Reference Stefani, Gerbeth, Gundrum, Hollerbach, Priede, Rüdiger and Szklarski2009). Current experimental work at the same device (Seilmayer et al.
Reference Seilmayer, Galindo, Gerbeth, Gundrum, Stefani, Gellert, Rüdiger, Schultz and Hollerbach2014) aims at the characterization of the azimuthal MRI (AMRI), a non-axisymmetric ‘relative’ of the axisymmetric HMRI, which dominates at large ratios of
 $B_{{\it\phi}}$
to
 $B_{z}$
(Hollerbach, Teeluck & Rüdiger Reference Hollerbach, Teeluck and Rüdiger2010). However, AMRI, as well as inductionless MRI modes with any other azimuthal wavenumber (which may be relevant at small values of
 $B_{{\it\phi}}/B_{z}$
), also seem to be constrained by the LLL as recently shown in a unified treatment of all inductionless versions of MRI by Kirillov, Stefani & Fukumoto (Reference Kirillov, Stefani and Fukumoto2012).
Actually, it is this apparent failure of HMRI, and AMRI, to apply to Keplerian profiles that has prevented a wider acceptance of those inductionless forms of MRI in the astrophysical community. Given the close proximity of the LLL (
 ${\approx}-0.83$
) and the Keplerian Rossby number (
 $-0.75$
), it is certainly worthwhile to ask whether any physically sensible modification would allow HMRI to extend to Keplerian flows.
Quite early, the validity of the LLL for
 $B_{{\it\phi}}(R)\propto 1/R$
had been questioned by Rüdiger & Hollerbach (Reference Rüdiger and Hollerbach2007). For the convective instability, they found an extension of the LLL to the Keplerian value in global simulations when at least one of the radial boundary conditions was assumed electrically conducting. Later, though, by extending the study to the absolute instability for travelling HMRI waves, the LLL was vindicated even for such modified electrical boundary conditions by Priede (Reference Priede2011). Kirillov & Stefani (Reference Kirillov and Stefani2011) made a second attempt by investigating HMRI for non-zero but low
 $S$
. For
 $B_{{\it\phi}}(R)\propto 1/R$
it was found that the essential HMRI mode extends from
 $S=0$
only to a value
 $S\approx 0.618$
, and allows a maximum Rossby number of
 $\mathit{Ro}\approx -0.802$
which is indeed slightly above the LLL, yet below the Keplerian value.
A third possibility may arise when considering that saturation of MRI could lead to modified flow structures with parts of steeper shear, sandwiched with parts of shallower shear (Umurhan Reference Umurhan2010).
A recent letter (Kirillov & Stefani Reference Kirillov and Stefani2013) has suggested another way of extending the range of applicability of the inductionless versions of MRI to Keplerian profiles, and beyond. Rather than relying on modified electrical boundary conditions, or on locally steepened
 ${\rm\Omega}(R)$
profiles, we have evaluated
 $B_{{\it\phi}}(R)$
profiles that are flatter than
 $1/R$
. The main physical idea behind this attempt is the following: assume that in some low-
 $\mathit{Pm}$
regions, characterized by
 $S\ll 1$
so that standard MRI is reliably suppressed,
 $\mathit{Rm}$
is still sufficiently large for inducing significant azimuthal magnetic fields, either from a prevalent axial field
 $B_{z}$
or by means of a dynamo process without any prescribed
 $B_{z}$
. Note that
 $B_{{\it\phi}}\propto 1/R$
would only appear in the extreme case of an isolated axial current, while the other extreme case,
 $B_{{\it\phi}}\propto R$
, would correspond to the case of a homogeneous axial current density in a fluid which is already prone to the kink-type Tayler instability (Seilmayer et al.
Reference Seilmayer, Stefani, Gundrum, Weier, Gerbeth, Gellert and Rüdiger2012), even at
 $\mathit{Re}=0$
.
Imagine now a real accretion disk with its complicated conductivity distributions in the radial and axial directions. For such real disks a large variety of intermediate
 $B_{{\it\phi}}(R)$
profiles between the extreme cases
 $\propto 1/R$
and
 $\propto R$
is easily conceivable. Instead of going into those details, one can ask which
 $B_{{\it\phi}}(R)$
profiles could make HMRI a viable mechanism for destabilizing Keplerian rotation profiles. By defining an appropriate magnetic Rossby number
 $\mathit{Rb}$
we have shown that the instability extends well beyond the LLL, even reaching
 $\mathit{Ro}=0$
when going to
 $\mathit{Rb}=-0.5$
. It should be noted that in this extreme case of uniform rotation the only available energy source of the instability is the magnetic field. On going into the region of positive
 $\mathit{Ro}$
in the
 $\mathit{Ro}{-}\mathit{Rb}$
plane, we then found a natural connection with the ULL which remains, so far, a somewhat mysterious conundrum.
The present paper represents a significant extension of the short letter (Kirillov & Stefani Reference Kirillov and Stefani2013). In the first instance, we will present a detailed derivation of the dispersion relation for arbitrary azimuthal modes in viscous resistive rotational flows under the influence of a constant axial and a superposed azimuthal field of arbitrary radial dependence. For this purpose, we employ general short-wavelength asymptotic series following Eckhoff (Reference Eckhoff1981, Reference Eckhoff1987), Bayly (Reference Bayly1988), Lifschitz (Reference Lifschitz1991), Lifschitz & Hameiri (Reference Lifschitz and Hameiri1991), Friedlander & Vishik (Reference Friedlander and Vishik1995), Vishik & Friedlander (Reference Vishik and Friedlander1998), Friedlander & Lipton-Lifschitz (Reference Friedlander, Lipton-Lifschitz, Friedlander and Serre2003), and Hattori & Fukumoto (Reference Hattori and Fukumoto2003) as well as a WKB approach of Kirillov & Stefani (Reference Kirillov and Stefani2010).
Second, we will discuss in much more detail the stability map in the
 $\mathit{Ro}{-}\mathit{Rb}$
-plane in the inductionless case of vanishing magnetic Prandtl number. For various limits we will discuss a number of strict results concerning the stability threshold and the growth rates. Special focus will be put on the role that is played by the line
 $\mathit{Ro}=\mathit{Rb}$
, and by the point
 $\mathit{Ro}=\mathit{Rb}=-\frac{2}{3}$
in particular.
Third, we will elaborate the dependence of the instability on the azimuthal wavenumber and on the ratio of the axial and radial wavenumbers and prove that the pattern of instability domains in the case of very small, but finite,
 $\mathit{Pm}$
is governed by a periodic band structure found in the inductionless limit.
Next, we will establish a connection between dissipation-induced destabilization of Chandrasekhar’s equipartition solution (a special solution for which the fluid velocity is parallel to the direction of the magnetic field and magnetic and kinetic energies are finite and equal (Chandrasekhar Reference Chandrasekhar1956, Reference Chandrasekhar1961)) and the azimuthal MRI, and we will explore the links between the Tayler instability and AMRI.
Last, but not least, we will delineate some possible astrophysical and experimental consequences of our findings, although a comprehensive discussion of the corresponding details must be left for future work.
2. Mathematical setting
2.1. Nonlinear equations
The standard set of nonlinear equations of dissipative incompressible magnetohydrodynamics consists of the Navier–Stokes equation for the fluid velocity
 $\boldsymbol{u}$
and of the induction equation for the magnetic field
 $\boldsymbol{B}$
:
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial \boldsymbol{u}}{\partial t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{u}-\displaystyle \frac{1}{{\it\mu}_{0}{\it\rho}}\boldsymbol{B}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{B}+\frac{1}{{\it\rho}}\boldsymbol{{\rm\nabla}}P-{\it\nu}{\rm\nabla}^{2}\boldsymbol{u}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial \boldsymbol{B}}{\partial t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{B}-\boldsymbol{B}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{u}-{\it\eta}{\rm\nabla}^{2}\boldsymbol{B}=0, & \displaystyle\end{eqnarray}$$
 $P=p+\boldsymbol{B}^{2}/2{\it\mu}_{0}$
is the total pressure,
 $p$
is the hydrodynamic pressure,
 ${\it\rho}=\text{const.}$
the density,
 ${\it\nu}=\text{const.}$
the kinematic viscosity,
 ${\it\eta}=({\it\mu}_{0}{\it\sigma})^{-1}$
the magnetic diffusivity,
 ${\it\sigma}$
the conductivity of the fluid, and
 ${\it\mu}_{0}$
the magnetic permeability of free space. Additionally, the mass continuity equation for incompressible flows and the solenoidal condition for the magnetic induction yield
 $$\begin{eqnarray}\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{u}=0,\quad \boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B}=0.\end{eqnarray}$$
2.2. Steady state
We consider the rotational fluid flow in the gap between the radii
 $R_{1}$
and
 $R_{2}>R_{1}$
, with an imposed magnetic field sustained by electrical currents. Introducing the cylindrical coordinates
 $(R,{\it\phi},z)$
we consider the stability of a steady-state background liquid flow with the angular velocity profile
 ${\rm\Omega}(R)$
in a helical background magnetic field (a magnetized Taylor–Couette (TC) flow):
 $$\begin{eqnarray}\boldsymbol{u}_{0}(R)=R\,{\rm\Omega}(R)\,\boldsymbol{e}_{{\it\phi}},\quad p=p_{0}(R),\quad \boldsymbol{B}_{0}(R)=B_{{\it\phi}}^{0}(R)\boldsymbol{e}_{{\it\phi}}+B_{z}^{0}\boldsymbol{e}_{z}.\end{eqnarray}$$
Note that if the azimuthal component is produced by an axial current
 $I$
confined to
 $R<R_{1}$
, then
 $$\begin{eqnarray}B_{{\it\phi}}^{0}(R)=\frac{{\it\mu}_{0}I}{2{\it\pi}R}.\end{eqnarray}$$
Introducing the hydrodynamic Rossby number
 $(\mathit{Ro})$
by means of the relation
 $$\begin{eqnarray}\mathit{Ro}:=\frac{R}{2{\rm\Omega}}\partial _{R}{\rm\Omega},\end{eqnarray}$$
where
 $\partial _{R}=\partial /\partial R$
, we find that the solid body rotation corresponds to
 $\mathit{Ro}=0$
and the Keplerian rotation to
 $\mathit{Ro}=-\frac{3}{4}$
, whereas the velocity profile
 ${\rm\Omega}(R)\sim R^{-2}$
corresponds to
 $\mathit{Ro}=-1$
. Note that although Keplerian rotation is not possible globally in TC-flow, an approximate Keplerian profile can locally be achieved.
Similarly, following Kirillov & Stefani (Reference Kirillov and Stefani2013) we define the magnetic Rossby number
 $$\begin{eqnarray}\mathit{Rb}:=\frac{R}{2B_{{\it\phi}}^{0}R^{-1}}\partial _{R}(B_{{\it\phi}}^{0}R^{-1}).\end{eqnarray}$$
 $\mathit{Rb}=0$
results from a linear dependence of the magnetic field on the radius,
 $B_{{\it\phi}}^{0}(R)\propto R$
, as would be produced by a homogeneous axial current in the fluid.
 $\mathit{Rb}=-1$
corresponds to the radial dependence given by (2.4). Note that the logarithmic derivatives
 ${\it\alpha}$
and
 ${\it\beta}$
introduced in the work by Ogilvie & Pringle (Reference Ogilvie and Pringle1996) are nothing else but the doubled hydrodynamic and magnetic Rossby numbers:
 ${\it\alpha}=2\mathit{Ro}$
,
 ${\it\beta}=2\mathit{Rb}$
.
2.3. Linearization with respect to non-axisymmetric perturbations
To describe natural oscillations in the neighbourhood of the magnetized Taylor–Couette flow we linearize equations (2.1)–(2.2) in the vicinity of the stationary solution (2.3) assuming general perturbations
 $\boldsymbol{u}=\boldsymbol{u}_{0}+\boldsymbol{u}^{\prime }$
,
 $p=p_{0}+p^{\prime }$
, and
 $\boldsymbol{B}=\boldsymbol{B}_{0}+\boldsymbol{B}^{\prime }$
and leaving only the terms of first order with respect to the primed quantities:
 $$\begin{eqnarray}\displaystyle & & \displaystyle \partial _{t}\boldsymbol{u}^{\prime }+\boldsymbol{u}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{u}^{\prime }+\boldsymbol{u}^{\prime }\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{u}_{0}-\frac{1}{{\it\rho}{\it\mu}_{0}}\left(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{B}^{\prime }+\boldsymbol{B}^{\prime }\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{B}_{0}\right)-{\it\nu}{\rm\nabla}^{2}\boldsymbol{u}^{\prime }\nonumber\\ \displaystyle & & \displaystyle \quad =-\frac{1}{{\it\rho}}\boldsymbol{{\rm\nabla}}p^{\prime }-\frac{1}{{\it\rho}{\it\mu}_{0}}\boldsymbol{{\rm\nabla}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{\prime }),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & & \displaystyle \partial _{t}\boldsymbol{B}^{\prime }+\boldsymbol{u}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{B}^{\prime }+\boldsymbol{u}^{\prime }\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{B}_{0}-\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{u}^{\prime }-\boldsymbol{B}^{\prime }\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{u}_{0}-{\it\eta}{\rm\nabla}^{2}\boldsymbol{B}^{\prime }=0,\end{eqnarray}$$
 $$\begin{eqnarray}\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{u}^{\prime }=0,\quad \boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B}^{\prime }=0.\end{eqnarray}$$
Note that by adding/subtracting (2.7b
) divided by
 $\sqrt{{\it\rho}{\it\mu}_{0}}$
to/from (2.7a
) yields the linearized equations in a more symmetrical Elsasser form; in the ideal magnetohydrodynamic (MHD) case they were derived e.g. by Friedlander & Vishik (Reference Friedlander and Vishik1995).
Introducing the gradients of the background fields represented by the two
 $3\times 3$
matrices
 $$\begin{eqnarray}\displaystyle & {\mathcal{U}}(R)=\boldsymbol{{\rm\nabla}}\boldsymbol{u}_{0}={\rm\Omega}\left(\begin{array}{@{}ccc@{}}0 & -1 & 0\\ 1+2\mathit{Ro} & 0 & 0\\ 0 & 0 & 0\\ \end{array}\right), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & {\mathcal{B}}(R)=\boldsymbol{{\rm\nabla}}\boldsymbol{B}_{0}=\displaystyle \frac{B_{{\it\phi}}^{0}}{R}\left(\begin{array}{@{}ccc@{}}0 & -1 & 0\\ 1+2\mathit{Rb} & 0 & 0\\ 0 & 0 & 0\\ \end{array}\right), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & & \displaystyle (\partial _{t}+{\mathcal{U}}+\boldsymbol{u}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{u}^{\prime }-\displaystyle \frac{1}{{\it\rho}{\it\mu}_{0}}\left({\mathcal{B}}+\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\right)\boldsymbol{B}^{\prime }\nonumber\\ \displaystyle & & \displaystyle \quad -\,{\it\nu}{\rm\nabla}^{2}\boldsymbol{u}^{\prime }+\displaystyle \frac{1}{{\it\rho}}\boldsymbol{{\rm\nabla}}p^{\prime }+\displaystyle \frac{1}{{\it\rho}{\it\mu}_{0}}\boldsymbol{{\rm\nabla}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{\prime })=0,\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & & \displaystyle (\partial _{t}-{\mathcal{U}}+\boldsymbol{u}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{B}^{\prime }+({\mathcal{B}}-\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{u}^{\prime }-{\it\eta}{\rm\nabla}^{2}\boldsymbol{B}^{\prime }=0.\end{eqnarray}$$
3. Geometrical optics equations
Following Eckhoff (Reference Eckhoff1981), Lifschitz (Reference Lifschitz1989, Reference Lifschitz1991) and Friedlander & Lipton-Lifschitz (Reference Friedlander, Lipton-Lifschitz, Friedlander and Serre2003), we seek solutions of the linearized equations (2.10) in terms of formal asymptotic series with respect to the small parameter
 ${\it\epsilon}$
,
 $0<{\it\epsilon}\ll 1$
:
 $$\begin{eqnarray}\displaystyle & \boldsymbol{u}^{\prime }(\boldsymbol{x},t,{\it\epsilon})=\text{e}^{\text{i}{\rm\Phi}(\boldsymbol{x},t)/{\it\epsilon}}\left(\boldsymbol{u}^{(0)}(\boldsymbol{x},t)+{\it\epsilon}\boldsymbol{u}^{(1)}(\boldsymbol{x},t)\right)+{\it\epsilon}\boldsymbol{u}^{(r)}(\boldsymbol{x},t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \boldsymbol{B}^{\prime }(\boldsymbol{x},t,{\it\epsilon})=\text{e}^{\text{i}{\rm\Phi}(\boldsymbol{x},t)/{\it\epsilon}}\left(\boldsymbol{B}^{(0)}(\boldsymbol{x},t)+{\it\epsilon}\boldsymbol{B}^{(1)}(\boldsymbol{x},t)\right)+{\it\epsilon}\boldsymbol{B}^{(r)}(\boldsymbol{x},t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & p^{\prime }(\boldsymbol{x},t,{\it\epsilon})=\text{e}^{\text{i}{\rm\Phi}(\boldsymbol{x},t)/{\it\epsilon}}\left(p^{(0)}(\boldsymbol{x},t)+{\it\epsilon}p^{(1)}(\boldsymbol{x},t)\right)+{\it\epsilon}p^{(r)}(\boldsymbol{x},t), & \displaystyle\end{eqnarray}$$
 $\boldsymbol{x}$
is a vector of coordinates,
 ${\rm\Phi}$
is a real-valued scalar function that represents the ‘fast’ phase of oscillations, and
 $\boldsymbol{u}^{(j)}$
,
 $\boldsymbol{B}^{(j)}$
and
 $p^{(j)}$
,
 $j=0,1,r$
, are ‘slow’ complex-valued amplitudes with the index
 $r$
denoting residual terms.
Following Landman & Saffman (Reference Landman and Saffman1987),
 $\!$
Lifschitz (Reference Lifschitz1991),
 $\!$
Dobrokhotov & Shafarevich (Reference Dobrokhotov and Shafarevich1992) and Eckhardt & Yao (Reference Eckhardt and Yao1995) we assume further on in the text that
 ${\it\nu}={\it\epsilon}^{2}\tilde{{\it\nu}}$
and
 ${\it\eta}={\it\epsilon}^{2}\tilde{{\it\eta}}$
and introduce the derivative along the fluid streamlines
 $$\begin{eqnarray}\frac{\text{D}}{\text{D}t}:=\partial _{t}+\boldsymbol{u}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}.\end{eqnarray}$$
Substituting expansions (3.1) into (2.10), taking into account the identity
 $$\begin{eqnarray}(\boldsymbol{A}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}){\rm\Phi}\boldsymbol{B}=(\boldsymbol{A}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})\boldsymbol{B}+{\rm\Phi}(\boldsymbol{A}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{B},\end{eqnarray}$$
as well as the relation
 $$\begin{eqnarray}{\rm\nabla}^{2}(\boldsymbol{u}^{\prime })=\text{e}^{\text{i}{\rm\Phi}/{\it\epsilon}}\left({\rm\nabla}^{2}+\text{i}\frac{2}{{\it\epsilon}}(\boldsymbol{{\rm\nabla}}{\rm\Phi}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})+\text{i}\frac{{\rm\nabla}^{2}{\rm\Phi}}{{\it\epsilon}}-\frac{(\boldsymbol{{\rm\nabla}}{\rm\Phi})^{2}}{{\it\epsilon}^{2}}\right)(\boldsymbol{u}^{(0)}+{\it\epsilon}\boldsymbol{u}^{(1)})+{\it\epsilon}{\rm\nabla}^{2}(\boldsymbol{u}^{(r)}),\end{eqnarray}$$
collecting terms at order
 ${\it\epsilon}^{-1}$
and
 ${\it\epsilon}^{0}$
we arrive at the system of local partial differential equations (cf. Friedlander & Vishik Reference Friedlander and Vishik1995)
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\text{D}{\rm\Phi}}{\text{D}t}\boldsymbol{u}^{(0)}-\displaystyle \frac{1}{{\it\rho}{\it\mu}_{0}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})\boldsymbol{B}^{(0)}+\frac{\boldsymbol{{\rm\nabla}}{\rm\Phi}}{{\it\rho}}\left(p^{(0)}+\frac{1}{{\it\mu}_{0}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{(0)})\right)=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\text{D}{\rm\Phi}}{\text{D}t}\boldsymbol{B}^{(0)}-(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})\boldsymbol{u}^{(0)}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \text{i}\frac{\text{D}{\rm\Phi}}{\text{D}t}\boldsymbol{u}^{(1)}-\frac{\text{i}}{{\it\rho}{\it\mu}_{0}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})\boldsymbol{B}^{(1)}+\displaystyle \text{i}\frac{\boldsymbol{{\rm\nabla}}{\rm\Phi}}{{\it\rho}}\left(p^{(1)}+\frac{1}{{\it\mu}_{0}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{(1)})\right) & \displaystyle \nonumber\\ \displaystyle & +\left(\displaystyle \frac{\text{D}}{\text{D}t}+\tilde{{\it\nu}}(\boldsymbol{{\rm\nabla}}{\rm\Phi})^{2}+{\mathcal{U}}\right)\boldsymbol{u}^{(0)}-\displaystyle \frac{1}{{\it\rho}{\it\mu}_{0}}\left({\mathcal{B}}+\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\right)\boldsymbol{B}^{(0)} & \displaystyle \nonumber\\ \displaystyle & +\,\displaystyle \frac{\boldsymbol{{\rm\nabla}}}{{\it\rho}}\left(p^{(0)}+\displaystyle \frac{1}{{\it\mu}_{0}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{(0)})\right)=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \text{i}\frac{\text{D}{\rm\Phi}}{\text{D}t}\boldsymbol{B}^{(1)}-\text{i}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})\boldsymbol{u}^{(1)}+\left(\frac{\text{D}}{\text{D}t}+\tilde{{\it\eta}}(\boldsymbol{{\rm\nabla}}{\rm\Phi})^{2}-{\mathcal{U}}\right)\boldsymbol{B}^{(0)} & \displaystyle \nonumber\\ \displaystyle & +\,({\mathcal{B}}-\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{u}^{(0)}=0. & \displaystyle\end{eqnarray}$$
From the solenoidality conditions (2.8) it follows that
 $$\begin{eqnarray}\boldsymbol{u}^{(0)}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi}=0,\quad \boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{u}^{(0)}+\text{i}\boldsymbol{u}^{(1)}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi}=0,\end{eqnarray}$$
 $$\begin{eqnarray}\boldsymbol{B}^{(0)}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi}=0,\quad \boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B}^{(0)}+\text{i}\boldsymbol{B}^{(1)}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi}=0.\end{eqnarray}$$
Following Lifschitz (Reference Lifschitz1991) we take the dot product of (3.5a
) and (3.5b
) with
 $\boldsymbol{{\rm\nabla}}{\rm\Phi}$
,
 $\boldsymbol{u}^{(0)}$
,
 $\boldsymbol{B}^{(0)}$
and, in view of the constraints (3.6), arrive at the system
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{(\boldsymbol{{\rm\nabla}}{\rm\Phi})^{2}}{{\it\rho}}\left(p^{(0)}+\frac{1}{{\it\mu}_{0}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{(0)})\right)=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\text{D}{\rm\Phi}}{\text{D}t}\boldsymbol{B}^{(0)}\boldsymbol{\cdot }\boldsymbol{B}^{(0)}-(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})\boldsymbol{u}^{(0)}\boldsymbol{\cdot }\boldsymbol{B}^{(0)}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\text{D}{\rm\Phi}}{\text{D}t}\boldsymbol{B}^{(0)}\boldsymbol{\cdot }\boldsymbol{u}^{(0)}-(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})\boldsymbol{u}^{(0)}\boldsymbol{\cdot }\boldsymbol{u}^{(0)}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\text{D}{\rm\Phi}}{\text{D}t}\boldsymbol{u}^{(0)}\boldsymbol{\cdot }\boldsymbol{B}^{(0)}-\displaystyle \frac{1}{{\it\rho}{\it\mu}_{0}}\boldsymbol{B}^{(0)}\boldsymbol{\cdot }\boldsymbol{B}^{(0)}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\text{D}{\rm\Phi}}{\text{D}t}\boldsymbol{u}^{(0)}\boldsymbol{\cdot }\boldsymbol{u}^{(0)}-\displaystyle \frac{1}{{\it\rho}{\it\mu}_{0}}\boldsymbol{B}^{(0)}\boldsymbol{\cdot }\boldsymbol{u}^{(0)}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi})=0, & \displaystyle\end{eqnarray}$$
 $\boldsymbol{{\rm\nabla}}{\rm\Phi}\neq 0$
,
 $\boldsymbol{B}^{(0)}\neq 0$
, and
 $\boldsymbol{u}^{(0)}\neq 0$
a particular solution
 $$\begin{eqnarray}p^{(0)}=-\frac{1}{{\it\mu}_{0}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{(0)}),\quad \frac{\text{D}{\rm\Phi}}{\text{D}t}=0,\quad \boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\rm\Phi}=0.\end{eqnarray}$$
With the use of the relations (3.8) we simplify (3.5c ) and (3.5d ) as
 $$\begin{eqnarray}\displaystyle & \displaystyle \left(\frac{\text{D}}{\text{D}t}+\tilde{{\it\nu}}(\boldsymbol{{\rm\nabla}}{\rm\Phi})^{2}+{\mathcal{U}}\right)\boldsymbol{u}^{(0)}-\displaystyle \frac{1}{{\it\rho}{\it\mu}_{0}}({\mathcal{B}}+\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{B}^{(0)} & \displaystyle \nonumber\\ \displaystyle & =-\displaystyle \text{i}\frac{\boldsymbol{{\rm\nabla}}{\rm\Phi}}{{\it\rho}}\left(p^{(1)}+\frac{1}{{\it\mu}_{0}}(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{(1)})\right), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \left(\frac{\text{D}}{\text{D}t}+\tilde{{\it\eta}}(\boldsymbol{{\rm\nabla}}{\rm\Phi})^{2}-{\mathcal{U}}\right)\boldsymbol{B}^{(0)}+({\mathcal{B}}-\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{u}^{(0)}=0. & \displaystyle\end{eqnarray}$$
 $\boldsymbol{{\rm\nabla}}{\rm\Phi}$
from the left and then dividing both parts by
 $|\boldsymbol{{\rm\nabla}}{\rm\Phi}|^{2}$
we find an expression for
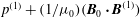 $p^{(1)}+(1/{\it\mu}_{0})(\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{B}^{(1)})$
. Substituting it back into the right-hand side of (3.9a
) and taking into account the constraints (3.6), we eliminate the pressure terms and transform this equation into
 $$\begin{eqnarray}\displaystyle & & \displaystyle \displaystyle \left(\frac{\text{D}}{\text{D}t}+\tilde{{\it\nu}}(\boldsymbol{{\rm\nabla}}{\rm\Phi})^{2}+{\mathcal{U}}\right)\boldsymbol{u}^{(0)}-\frac{1}{{\it\rho}{\it\mu}_{0}}({\mathcal{B}}+\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{B}^{(0)}\nonumber\\ \displaystyle & & \displaystyle \quad =\displaystyle \frac{\boldsymbol{{\rm\nabla}}{\rm\Phi}}{|\boldsymbol{{\rm\nabla}}{\rm\Phi}|^{2}}\boldsymbol{\cdot }\left[\left(\frac{\text{D}}{\text{D}t}+{\mathcal{U}}\right)\boldsymbol{u}^{(0)}-\displaystyle \frac{1}{{\it\rho}{\it\mu}_{0}}({\mathcal{B}}+\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{B}^{(0)}\right]\boldsymbol{{\rm\nabla}}{\rm\Phi},\end{eqnarray}$$
in accordance with the standard procedure described e.g. in Lifschitz (Reference Lifschitz1991) and Vishik & Friedlander (Reference Vishik and Friedlander1998). Differentiating identity (3.6a ) yields
 $$\begin{eqnarray}\frac{\text{D}}{\text{D}t}(\boldsymbol{{\rm\nabla}}{\rm\Phi}\boldsymbol{\cdot }\boldsymbol{u}^{(0)})=\frac{\text{D}\boldsymbol{{\rm\nabla}}{\rm\Phi}}{\text{D}t}\boldsymbol{\cdot }\boldsymbol{u}^{(0)}+\boldsymbol{{\rm\nabla}}{\rm\Phi}\boldsymbol{\cdot }\frac{\text{D}\boldsymbol{u}^{(0)}}{\text{D}t}=0.\end{eqnarray}$$
Using the identity (3.11), we re-write (3.10) as follows:
 $$\begin{eqnarray}\displaystyle & & \displaystyle \displaystyle \left(\frac{\text{D}}{\text{D}t}+\tilde{{\it\nu}}(\boldsymbol{{\rm\nabla}}{\rm\Phi})^{2}+{\mathcal{U}}\right)\boldsymbol{u}^{(0)}-\frac{1}{{\it\rho}{\it\mu}_{0}}({\mathcal{B}}+\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{B}^{(0)}\nonumber\\ \displaystyle & & \displaystyle \displaystyle \quad =\frac{\boldsymbol{{\rm\nabla}}{\rm\Phi}}{|\boldsymbol{{\rm\nabla}}{\rm\Phi}|^{2}}\boldsymbol{\cdot }\left[{\mathcal{U}}\boldsymbol{u}^{(0)}-\frac{1}{{\it\rho}{\it\mu}_{0}}({\mathcal{B}}+\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{B}^{(0)}\right]\boldsymbol{{\rm\nabla}}{\rm\Phi}-\frac{\boldsymbol{{\rm\nabla}}{\rm\Phi}}{|\boldsymbol{{\rm\nabla}}{\rm\Phi}|^{2}}\frac{\text{D}\boldsymbol{{\rm\nabla}}{\rm\Phi}}{\text{D}t}\boldsymbol{\cdot }\boldsymbol{u}^{(0)}.\end{eqnarray}$$
Now we take the gradient of the identity
 $\text{D}{\rm\Phi}/\text{D}t=0$
:
 $$\begin{eqnarray}\displaystyle \boldsymbol{{\rm\nabla}}\partial _{t}{\rm\Phi}+\boldsymbol{{\rm\nabla}}(\boldsymbol{u}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}){\rm\Phi} & = & \displaystyle \partial _{t}\boldsymbol{{\rm\nabla}}{\rm\Phi}+(\boldsymbol{u}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{{\rm\nabla}}{\rm\Phi}+{\mathcal{U}}^{\text{T}}\boldsymbol{{\rm\nabla}}{\rm\Phi}\nonumber\\ \displaystyle & = & \displaystyle \frac{\text{D}}{\text{D}t}\boldsymbol{{\rm\nabla}}{\rm\Phi}+{\mathcal{U}}^{\text{T}}\boldsymbol{{\rm\nabla}}{\rm\Phi}=0.\end{eqnarray}$$
Denoting
 $\boldsymbol{k}=\boldsymbol{{\rm\nabla}}{\rm\Phi}$
, we deduce from the phase equation (3.13) that
 $$\begin{eqnarray}\frac{\text{D}\boldsymbol{k}}{\text{D}t}=-{\mathcal{U}}^{\text{T}}\boldsymbol{k}.\end{eqnarray}$$
Hence, the transport equations for the amplitudes (3.9) take the final form
 $$\begin{eqnarray}\displaystyle \displaystyle \frac{\text{D}\boldsymbol{u}^{(0)}}{\text{D}t} & = & \displaystyle -\left(\unicode[STIX]{x1D644}-2\frac{\boldsymbol{k}\boldsymbol{k}^{\text{T}}}{|\boldsymbol{k}|^{2}}\right){\mathcal{U}}\boldsymbol{u}^{(0)}-\tilde{{\it\nu}}|\boldsymbol{k}|^{2}\boldsymbol{u}^{(0)}\nonumber\\ \displaystyle & & \displaystyle +\,\frac{1}{{\it\rho}{\it\mu}_{0}}\left(\unicode[STIX]{x1D644}-\frac{\boldsymbol{k}\boldsymbol{k}^{\text{T}}}{|\boldsymbol{k}|^{2}}\right)\left({\mathcal{B}}+\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\right)\boldsymbol{B}^{(0)},\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \displaystyle \frac{\text{D}\boldsymbol{B}^{(0)}}{\text{D}t} & = & \displaystyle {\mathcal{U}}\boldsymbol{B}^{(0)}-\tilde{{\it\eta}}|\boldsymbol{k}|^{2}\boldsymbol{B}^{(0)}-({\mathcal{B}}-\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}})\boldsymbol{u}^{(0)},\end{eqnarray}$$
 $\unicode[STIX]{x1D644}$
is a
 $3\times 3$
identity matrix.
Equations (3.15) are local partial differential equations analogous to those derived (in terms of Elsasser variables
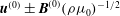 $\boldsymbol{u}^{(0)}\pm \boldsymbol{B}^{(0)}({\it\rho}{\it\mu}_{0})^{-1/2}$
) by Friedlander & Vishik (Reference Friedlander and Vishik1995) who considered non-axisymmetric perturbation of a rotating flow of an ideal incompressible fluid which is a perfect electrical conductor in the presence of an azimuthal magnetic field of arbitrary radial and axial dependence, see appendix A.
In the absence of the magnetic field these equations can be treated as ordinary differential equations with respect to the convective derivative (3.2) and thus are reduced to that of Eckhardt & Yao (Reference Eckhardt and Yao1995) who considered stability of the viscous TC-flow. Note that the same form of the transport equations (with the different matrix
 ${\mathcal{U}}$
) appears in the studies of elliptical instability by Landman & Saffman (Reference Landman and Saffman1987) and of three-dimensional local instabilities of more general viscous and inviscid basic flows by Lifschitz (Reference Lifschitz1991), Lifschitz & Hameiri (Reference Lifschitz and Hameiri1991), and Dobrokhotov & Shafarevich (Reference Dobrokhotov and Shafarevich1992).
4. Dispersion relation of AMRI
In the case when the axial field is absent, i.e.
 $B_{z}^{0}=0$
, we can derive the dispersion relation of AMRI directly from the transport equations (3.15) according to the procedure described in Friedlander & Vishik (Reference Friedlander and Vishik1995).
Let the orthogonal unit vectors
 $\boldsymbol{e}_{R}(t)$
,
 $\boldsymbol{e}_{{\it\phi}}(t)$
and
 $\boldsymbol{e}_{z}(t)$
form a basis in a cylindrical coordinate system moving along the fluid trajectory. With
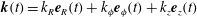 $\boldsymbol{k}(t)=k_{R}\boldsymbol{e}_{R}(t)+k_{{\it\phi}}\boldsymbol{e}_{{\it\phi}}(t)+k_{z}\boldsymbol{e}_{z}(t)$
,
 $\boldsymbol{u}(t)=u_{R}\boldsymbol{e}_{R}(t)+u_{{\it\phi}}\boldsymbol{e}_{{\it\phi}}(t)+u_{z}\boldsymbol{e}_{z}(t)$
, and with the matrix
 ${\mathcal{U}}$
from (2.9), we find
 $$\begin{eqnarray}\dot{\boldsymbol{e}}_{R}={\rm\Omega}(R)\mathbf{e}_{{\it\phi}},\quad \dot{\boldsymbol{e}}_{{\it\phi}}=-{\rm\Omega}(R)\boldsymbol{e}_{R}.\end{eqnarray}$$
Hence, the equation (3.14) in the coordinate form is
 $$\begin{eqnarray}\dot{k}_{R}=-R\partial _{R}{\rm\Omega}k_{{\it\phi}},\quad \dot{k}_{{\it\phi}}=0,\quad \dot{k}_{z}=0.\end{eqnarray}$$
According to Eckhardt & Yao (Reference Eckhardt and Yao1995) and Friedlander & Vishik (Reference Friedlander and Vishik1995), in order to study physically relevant and potentially unstable modes we have to choose bounded and asymptotically non-decaying solutions of the system (4.2). These correspond to
 $k_{{\it\phi}}\equiv 0$
and
 $k_{R}$
and
 $k_{z}$
time-independent. Note that when
 $B_{z}^{0}=0$
this solution is compatible with the constraint
 $\boldsymbol{B}_{0}\boldsymbol{\cdot }\boldsymbol{k}=0$
following from (3.8).
Denoting
 ${\it\alpha}=k_{z}|\boldsymbol{k}|^{-1}$
, where
 $|\boldsymbol{k}|^{2}=k_{R}^{2}+k_{z}^{2}$
, we find that
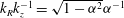 $k_{R}k_{z}^{-1}=\sqrt{1-{\it\alpha}^{2}}{\it\alpha}^{-1}$
and write the local partial differential equations (3.15) for the amplitudes in the coordinate representation. Analogously to Friedlander & Vishik (Reference Friedlander and Vishik1995), we single out the equations for the radial and azimuthal components of the fluid velocity and magnetic field by using the orthogonality condition
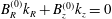 $B_{R}^{(0)}k_{R}+B_{z}^{(0)}k_{z}=0$
that follows from (3.6):
 $$\begin{eqnarray}\displaystyle & \displaystyle \left(\partial _{t}+{\rm\Omega}\partial _{{\it\phi}}+\widetilde{{\it\nu}}|\boldsymbol{k}|^{2}\right)u_{R}^{(0)}-2{\it\alpha}^{2}{\rm\Omega}u_{{\it\phi}}^{(0)}+2{\it\alpha}^{2}\frac{B_{{\it\phi}}^{0}}{{\it\rho}{\it\mu}_{0}R}B_{{\it\phi}}^{(0)}-\frac{B_{{\it\phi}}^{0}}{R}\frac{\partial _{{\it\phi}}B_{R}^{(0)}}{{\it\rho}{\it\mu}_{0}}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \left(\partial _{t}+{\rm\Omega}\partial _{{\it\phi}}+\widetilde{{\it\nu}}|\boldsymbol{k}|^{2}\right)u_{{\it\phi}}^{(0)}+2{\rm\Omega}(1+\mathit{Ro})u_{R}^{(0)}-\frac{2}{{\it\rho}{\it\mu}_{0}}\frac{B_{{\it\phi}}^{0}}{R}(1+\mathit{Rb})B_{R}^{(0)}-\frac{B_{{\it\phi}}^{0}}{R}\frac{\partial _{{\it\phi}}B_{{\it\phi}}^{(0)}}{{\it\rho}{\it\mu}_{0}}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \left(\partial _{t}+{\rm\Omega}\partial _{{\it\phi}}+\widetilde{{\it\eta}}|\boldsymbol{k}|^{2}\right)B_{R}^{(0)}-\frac{B_{{\it\phi}}^{0}}{R}\partial _{{\it\phi}}u_{R}^{(0)}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \left(\partial _{t}+{\rm\Omega}\partial _{{\it\phi}}+\widetilde{{\it\eta}}|\boldsymbol{k}|^{2}\right)B_{{\it\phi}}^{(0)}-2{\rm\Omega}\mathit{Ro}B_{R}^{(0)}+2\mathit{Rb}\frac{B_{{\it\phi}}^{0}}{R}u_{R}^{(0)}-\frac{B_{{\it\phi}}^{0}}{R}\partial _{{\it\phi}}u_{{\it\phi}}^{(0)}=0. & \displaystyle\end{eqnarray}$$
According to Friedlander & Vishik (Reference Friedlander and Vishik1995) a natural step is to seek a solution to (4.3) in the modal form
 $\boldsymbol{ u}^{(0)}=\widehat{\boldsymbol{u}}\text{e}^{{\it\gamma}t+\text{i}m{\it\phi}}$
,
 $\boldsymbol{ B}^{(0)}=\widehat{\boldsymbol{B}}\text{e}^{{\it\gamma}t+\text{i}m{\it\phi}}$
in order to end up with the dispersion relation for the transport equations in the case of AMRI:
 $$\begin{eqnarray}\displaystyle & \displaystyle ({\it\gamma}+\text{i}m{\rm\Omega}+\widetilde{{\it\nu}}|\boldsymbol{k}|^{2})\widehat{u}_{R}-2{\it\alpha}^{2}{\rm\Omega}\widehat{u}_{{\it\phi}}+2{\it\alpha}^{2}\frac{B_{{\it\phi}}^{0}}{{\it\rho}{\it\mu}_{0}R}\widehat{B}_{{\it\phi}}-\text{i}m\frac{B_{{\it\phi}}^{0}}{R}\frac{\widehat{B}_{R}}{{\it\rho}{\it\mu}_{0}}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle ({\it\gamma}+\text{i}m{\rm\Omega}+\widetilde{{\it\nu}}|\boldsymbol{k}|^{2})\widehat{u}_{{\it\phi}}+2{\rm\Omega}(1+\mathit{Ro})\widehat{u}_{R}-\frac{2}{{\it\rho}{\it\mu}_{0}}\frac{B_{{\it\phi}}^{0}}{R}(1+\mathit{Rb})\widehat{B}_{R}-\text{i}m\frac{B_{{\it\phi}}^{0}}{R}\frac{\widehat{B}_{{\it\phi}}}{{\it\rho}{\it\mu}_{0}}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle ({\it\gamma}+\text{i}m{\rm\Omega}+\widetilde{{\it\eta}}|\boldsymbol{k}|^{2})\widehat{B}_{R}-\text{i}m\frac{B_{{\it\phi}}^{0}}{R}\widehat{u}_{R}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle ({\it\gamma}+\text{i}m{\rm\Omega}+\widetilde{{\it\eta}}|\boldsymbol{k}|^{2})\widehat{B}_{{\it\phi}}-2{\rm\Omega}\mathit{Ro}\widehat{B}_{R}+2\mathit{Rb}\frac{B_{{\it\phi}}^{0}}{R}\widehat{u}_{R}-\text{i}m\frac{B_{{\it\phi}}^{0}}{R}\widehat{u}_{{\it\phi}}=0. & \displaystyle\end{eqnarray}$$
Introducing the viscous and resistive frequencies and the Alfvén angular velocity (Ogilvie & Pringle Reference Ogilvie and Pringle1996) corresponding to the azimuthal magnetic field:
 $$\begin{eqnarray}{\it\omega}_{{\it\nu}}=\widetilde{{\it\nu}}|\boldsymbol{k}|^{2},\quad {\it\omega}_{{\it\eta}}=\widetilde{{\it\eta}}|\boldsymbol{k}|^{2},\quad {\it\omega}_{A_{{\it\phi}}}=\frac{B_{{\it\phi}}^{0}}{R\sqrt{{\it\rho}{\it\mu}_{0}}},\end{eqnarray}$$
so that
 $\mathit{Rb}$
is simply
 $$\begin{eqnarray}\mathit{Rb}=\frac{R}{2{\it\omega}_{A_{{\it\phi}}}}\partial _{R}{\it\omega}_{A_{{\it\phi}}},\end{eqnarray}$$
we write the amplitude equations (4.4) as
 $\unicode[STIX]{x1D63C}\boldsymbol{z}={\it\gamma}\boldsymbol{z}$
, where
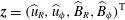 $\boldsymbol{ z}=(\widehat{u}_{R},\widehat{u}_{{\it\phi}},\widehat{B}_{R},\widehat{B}_{{\it\phi}})^{\text{T}}$
and
 $$\begin{eqnarray}\unicode[STIX]{x1D63C}=\left(\begin{array}{@{}cccc@{}}-\text{i}m{\rm\Omega}-{\it\omega}_{{\it\nu}} & 2{\it\alpha}^{2}{\rm\Omega} & \text{i}\displaystyle \frac{m{\it\omega}_{A_{{\it\phi}}}}{\sqrt{{\it\rho}{\it\mu}_{0}}} & \displaystyle -\frac{2{\it\omega}_{A_{{\it\phi}}}{\it\alpha}^{2}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\\ -2{\rm\Omega}(1+\mathit{Ro}) & -\text{i}m{\rm\Omega}-{\it\omega}_{{\it\nu}} & \displaystyle \frac{2{\it\omega}_{A_{{\it\phi}}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}(1+\mathit{Rb}) & \displaystyle \text{i}\frac{m{\it\omega}_{A_{{\it\phi}}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\\ \text{i}m{\it\omega}_{A_{{\it\phi}}}\sqrt{{\it\rho}{\it\mu}_{0}} & 0 & -\text{i}m{\rm\Omega}-{\it\omega}_{{\it\eta}} & 0\\ -2{\it\omega}_{A_{{\it\phi}}}\mathit{Rb}\sqrt{{\it\rho}{\it\mu}_{0}} & \text{i}m{\it\omega}_{A_{{\it\phi}}}\sqrt{{\it\rho}{\it\mu}_{0}} & 2{\rm\Omega}\mathit{Ro} & -\text{i}m{\rm\Omega}-{\it\omega}_{{\it\eta}}\\ \end{array}\right).\end{eqnarray}$$
In the case when
 ${\it\omega}_{{\it\nu}}=0$
and
 ${\it\omega}_{{\it\eta}}=0$
the coefficients of the characteristic polynomial of the matrix (4.7) exactly coincide with the dispersion relation of ideal AMRI derived by Friedlander & Vishik (Reference Friedlander and Vishik1995), see appendix A for the detailed comparison.
5. Dispersion relation of HMRI
It is instructive to derive the dispersion relation of HMRI by another approach similar to that of Kirillov & Stefani (Reference Kirillov and Stefani2010).
We write the linearized equations (2.10) in cylindrical coordinates
 $(R,{\it\phi},z)$
and assume that
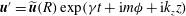 $\boldsymbol{u}^{\prime }=\widetilde{\boldsymbol{u}}(R)\exp ({\it\gamma}t+\text{i}m{\it\phi}+\text{i}k_{z}z)$
,
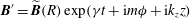 $\boldsymbol{B}^{\prime }=\widetilde{\boldsymbol{B}}(R)\exp ({\it\gamma}t+\text{i}m{\it\phi}+\text{i}k_{z}z)$
, and
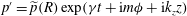 $p^{\prime }=\widetilde{p}(R)\exp ({\it\gamma}t+\text{i}m{\it\phi}+\text{i}k_{z}z)$
. This yields a set of equations containing only functions of
 $R$
and radial derivatives:
 $$\begin{eqnarray}\displaystyle & \displaystyle \left(\begin{array}{@{}ccc@{}}{\it\gamma}+\text{i}m{\rm\Omega}-{\it\nu}\text{D} & -2{\rm\Omega} & 0\\ 2(1+\mathit{Ro}) & {\it\gamma}+\text{i}m{\rm\Omega}-{\it\nu}\text{D} & 0\\ 0 & 0 & {\it\gamma}+\text{i}m{\rm\Omega}-{\it\nu}\text{D}\\ \end{array}\right)\widetilde{\boldsymbol{u}}-\frac{{\it\nu}}{R^{2}}\left(\begin{array}{@{}ccc@{}}-1 & -2\text{i}m & 0\\ 2\text{i}m & -1 & 0\\ 0 & 0 & 0\\ \end{array}\right)\widetilde{\boldsymbol{u}} & \displaystyle \nonumber\\ \displaystyle & -\,\displaystyle \frac{B_{{\it\phi}}^{0}}{{\it\rho}{\it\mu}_{0}R}\left(\begin{array}{@{}ccc@{}}\text{i}m & -2 & 0\\ 2(1+\mathit{Rb}) & \text{i}m & 0\\ 0 & 0 & \text{i}m\\ \end{array}\right)\widetilde{\boldsymbol{B}}-\frac{B_{z}^{0}}{{\it\rho}{\it\mu}_{0}}\left(\begin{array}{@{}ccc@{}}\text{i}k_{z} & 0 & 0\\ 0 & \text{i}k_{z} & 0\\ 0 & 0 & \text{i}k_{z}\\ \end{array}\right)\widetilde{\boldsymbol{B}} & \displaystyle \nonumber\\ \displaystyle & +\,\displaystyle \left(\begin{array}{@{}ccc@{}}\partial _{R} & 0 & 0\\ 0 & \displaystyle \frac{\text{i}m}{R} & 0\\ 0 & 0 & \text{i}k_{z}\\ \end{array}\right)\widetilde{p}+\frac{1}{{\it\rho}{\it\mu}_{0}}\left(\begin{array}{@{}ccc@{}}0 & \displaystyle \frac{B_{{\it\phi}}^{0}}{R}(1+2\mathit{Rb})+B_{{\it\phi}}^{0}\partial _{R} & B_{z}^{0}\partial _{R}\\ 0 & \displaystyle \frac{\text{i}m}{R}B_{{\it\phi}}^{0} & \displaystyle \frac{\text{i}m}{R}B_{z}^{0}\\ 0 & \text{i}k_{z}B_{{\it\phi}}^{0} & \text{i}k_{z}B_{z}^{0}\\ \end{array}\right)\widetilde{\boldsymbol{B}}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \left(\begin{array}{@{}ccc@{}}{\it\gamma}+\text{i}m{\rm\Omega}-{\it\eta}\text{D} & 0 & 0\\ -2{\rm\Omega}\mathit{Ro} & {\it\gamma}+\text{i}m{\rm\Omega}-{\it\eta}\text{D} & 0\\ 0 & 0 & {\it\gamma}+\text{i}m{\rm\Omega}-{\it\eta}\text{D}\\ \end{array}\right)\widetilde{\boldsymbol{B}}-\frac{{\it\eta}}{R^{2}}\left(\begin{array}{@{}ccc@{}}-1 & -2\text{i}m & 0\\ 2\text{i}m & -1 & 0\\ 0 & 0 & 0\\ \end{array}\right)\widetilde{\boldsymbol{B}} & \displaystyle \nonumber\\ \displaystyle & -\,\displaystyle \frac{B_{{\it\phi}}^{0}}{R}\left(\begin{array}{@{}ccc@{}}\text{i}m & 0 & 0\\ -2\mathit{Rb } & \text{i}m & 0\\ 0 & 0 & \text{i}m\\ \end{array}\right)\widetilde{\boldsymbol{u}}-B_{z}^{0}\left(\begin{array}{@{}ccc@{}}\text{i}k_{z} & 0 & 0\\ 0 & \text{i}k_{z} & 0\\ 0 & 0 & \text{i}k_{z}\\ \end{array}\right)\widetilde{\boldsymbol{u}}=0, & \displaystyle\end{eqnarray}$$
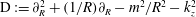 $\text{D}:=\partial _{R}^{2}+(1/R)\partial _{R}-m^{2}/R^{2}-k_{z}^{2}$
. The same operation applied to (2.8) yields
 $$\begin{eqnarray}\frac{\widetilde{u}_{R}}{R}+\partial _{R}\widetilde{u}_{R}+\frac{\text{i}m}{R}\widetilde{u}_{{\it\phi}}+\text{i}k_{z}\widetilde{u}_{z}=0,\quad \frac{\widetilde{B}_{R}}{R}+\partial _{R}\widetilde{B}_{R}+\frac{\text{i}m}{R}\widetilde{B}_{{\it\phi}}+\text{i}k_{z}\widetilde{B}_{z}=0.\end{eqnarray}$$
Note that the equation determined by the third row of the matrix equation (5.2) is already separated from the others.
Substituting
 $\widetilde{\boldsymbol{u}}(R)=\widehat{\boldsymbol{u}}\text{e}^{\text{i}k_{R}R}$
and
 $\widetilde{\boldsymbol{B}}(R)=\widehat{\boldsymbol{B}}\text{e}^{\text{i}k_{R}R}$
into (5.2) and assuming that
 $R$
is fixed for a local analysis, we introduce into the resulting equations the parameters
 $$\begin{eqnarray}{\it\omega}_{A_{z}}=\frac{k_{z}B_{z}^{0}}{\sqrt{{\it\rho}{\it\mu}_{0}}},\quad {\it\omega}_{A_{{\it\phi}}}=\frac{B_{{\it\phi}}^{0}}{R\sqrt{{\it\rho}{\it\mu}_{0}}},\quad {\it\omega}_{{\it\nu}}={\it\nu}|\boldsymbol{k}|^{2},\quad {\it\omega}_{{\it\eta}}={\it\eta}|\boldsymbol{k}|^{2},\quad |\boldsymbol{k}|^{2}=k_{R}^{2}+k_{z}^{2},\end{eqnarray}$$
and finally set, in these re-parameterized equations,
 $R=({\it\epsilon}k_{R})^{-1}$
, where
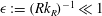 ${\it\epsilon}:=(Rk_{R})^{-1}\ll 1$
is a small parameter. After expanding the result in powers of
 ${\it\epsilon}$
, we find that the equations determined by the first two rows of the matrix equation (5.2) take the form
 $$\begin{eqnarray}\displaystyle & -\text{i}\sqrt{{\it\rho}{\it\mu}_{0}}(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})\widehat{u}_{R}+({\it\gamma}+{\it\omega}_{{\it\eta}}+\text{i}m{\rm\Omega})\widehat{B}_{R}=O({\it\epsilon}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & 2{\it\omega}_{A_{{\it\phi}}}\mathit{Rb}\sqrt{{\it\rho}{\it\mu}_{0}}\widehat{u}_{R}-\text{i}(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})\sqrt{{\it\rho}{\it\mu}_{0}}\widehat{u}_{{\it\phi}} & \displaystyle \nonumber\\ \displaystyle & \quad -\,2{\rm\Omega}\mathit{Ro}\widehat{B}_{R}+({\it\gamma}+{\it\omega}_{{\it\eta}}+\text{i}m{\rm\Omega})\widehat{B}_{{\it\phi}}=O({\it\epsilon}). & \displaystyle\end{eqnarray}$$
Next, we express the pressure term from the third row of equation (5.1) as follows:
 $$\begin{eqnarray}\widetilde{p}=\frac{\text{i}}{k_{z}}\left(({\it\gamma}+\text{i}m{\rm\Omega}-{\it\nu}\text{D})\widetilde{u}_{z}-\frac{\text{i}mB_{{\it\phi}}^{0}}{{\it\rho}{\it\mu}_{0}R}\widetilde{B}_{z}+\frac{\text{i}k_{z}B_{{\it\phi}}^{0}}{{\it\rho}{\it\mu}_{0}}\widetilde{B}_{{\it\phi}}\right).\end{eqnarray}$$
Analogously, finding
 $\widetilde{u}_{z}$
and
 $\widetilde{B}_{z}$
from (5.3) we substitute these terms together with the pressure term (5.6) into the first two rows of equation (5.1), assume in the result that
 $\widetilde{\boldsymbol{u}}(R)=\widehat{\boldsymbol{u}}\text{e}^{\text{i}k_{R}R}$
and
 $\widetilde{\boldsymbol{B}}(R)=\widehat{\boldsymbol{B}}\text{e}^{\text{i}k_{R}R}$
and take into account expressions (5.4). Then setting
 $R=({\it\epsilon}k_{R})^{-1}$
in the equations and expanding them in
 ${\it\epsilon}$
, we obtain
 $$\begin{eqnarray}\displaystyle & & \displaystyle \displaystyle ({\it\gamma}+{\it\omega}_{{\it\nu}}+\text{i}m{\rm\Omega})\frac{k_{R}^{2}+k_{z}^{2}}{k_{z}^{2}}\widehat{u}_{R}-2{\rm\Omega}\widehat{u}_{{\it\phi}}\nonumber\\ \displaystyle & & \displaystyle \quad -\,\displaystyle \text{i}\frac{m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\displaystyle \frac{k_{R}^{2}+k_{z}^{2}}{k_{z}^{2}}\widehat{B}_{R}+\displaystyle \frac{2{\it\omega}_{A_{{\it\phi}}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\widehat{B}_{{\it\phi}}=O({\it\epsilon}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & & \displaystyle \displaystyle 2{\rm\Omega}(1+\mathit{Ro})\widehat{u}_{R}+({\it\gamma}+{\it\omega}_{{\it\nu}}+\text{i}m{\rm\Omega})\widehat{u}_{{\it\phi}}\nonumber\\ \displaystyle & & \displaystyle \quad -\,2(1+\mathit{Rb})\displaystyle \frac{{\it\omega}_{A_{{\it\phi}}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\widehat{B}_{R}-\text{i}\displaystyle \frac{m{\it\omega}_{Af}+{\it\omega}_{A_{z}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\widehat{B}_{{\it\phi}}=O({\it\epsilon}).\end{eqnarray}$$
 $\unicode[STIX]{x1D643}\boldsymbol{z}={\it\gamma}\boldsymbol{z}$
with
 $\boldsymbol{z}=(\widehat{u}_{R},\widehat{u}_{{\it\phi}},\widehat{B}_{R},\widehat{B}_{{\it\phi}})^{\text{T}}$
and (cf. Kirillov & Stefani Reference Kirillov and Stefani2013; Squire & Bhattacharjee Reference Squire and Bhattacharjee2014)
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D643}=\left(\begin{array}{@{}cccc@{}}-\text{i}m{\rm\Omega}-{\it\omega}_{{\it\nu}} & 2{\it\alpha}^{2}{\rm\Omega} & \text{i}\displaystyle \frac{m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}}}{\sqrt{{\it\rho}{\it\mu}_{0}}} & \displaystyle -\frac{2{\it\omega}_{A_{{\it\phi}}}{\it\alpha}^{2}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\\ -2{\rm\Omega}(1+\mathit{Ro}) & -\text{i}m{\rm\Omega}-{\it\omega}_{{\it\nu}} & \displaystyle \frac{2{\it\omega}_{A_{{\it\phi}}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}(1+\mathit{Rb}) & \displaystyle \text{i}\frac{m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\\ \text{i}(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})\sqrt{{\it\rho}{\it\mu}_{0}} & 0 & -\text{i}m{\rm\Omega}-{\it\omega}_{{\it\eta}} & 0\\ -2{\it\omega}_{A_{{\it\phi}}}\mathit{Rb}\sqrt{{\it\rho}{\it\mu}_{0}} & \text{i}(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})\sqrt{{\it\rho}{\it\mu}_{0}} & 2{\rm\Omega}\mathit{Ro} & -\text{i}m{\rm\Omega}-{\it\omega}_{{\it\eta}}\end{array}\right), & & \displaystyle\end{eqnarray}$$
where
 ${\it\alpha}=k_{z}|\boldsymbol{k}|^{-1}$
and
 ${\it\omega}_{A_{z}}$
is the Alfvén frequency associated with the axial component of the magnetic field. When
 ${\it\omega}_{A_{z}}=0$
, the matrix (5.8) coincides with the matrix (4.7).
The dispersion relation of HMRI
 $$\begin{eqnarray}p({\it\gamma}):=\det (\unicode[STIX]{x1D643}-{\it\gamma}\unicode[STIX]{x1D644})=0,\end{eqnarray}$$
where
 $\unicode[STIX]{x1D644}$
is the
 $4\times 4$
identity matrix, is the fourth-order polynomial
 $$\begin{eqnarray}p({\it\gamma})=(a_{0}+\text{i}b_{0}){\it\gamma}^{4}+(a_{1}+\text{i}b_{1}){\it\gamma}^{3}+(a_{2}+\text{i}b_{2}){\it\gamma}^{2}+(a_{3}+\text{i}b_{3}){\it\gamma}+a_{4}+\text{i}b_{4}\end{eqnarray}$$
with complex coefficients that are given in explicit form by (B 1) in appendix B.
In the presence of the magnetic fields with
 $\mathit{Rb}=-1$
, the dispersion relation (5.9) reduces to that derived by Kirillov et al. (Reference Kirillov, Stefani and Fukumoto2012) and in the case when
 $\mathit{Rb}=-1$
and
 $m=0$
to that of Kirillov & Stefani (Reference Kirillov and Stefani2010). In the ideal MHD case this dispersion relation has already been obtained by Ogilvie & Pringle (Reference Ogilvie and Pringle1996). In the absence of the magnetic fields, the dispersion relation (5.9) reduces to that derived in the narrow-gap approximation by Krueger, Gross & Di Prima (Reference Krueger, Gross and Di Prima1966) for non-axisymmetric perturbations of the hydrodynamic TC-flow. Explicitly, this connection is established in appendix C.
6. Connection to known stability and instability criteria
Let us compose a matrix filled with the coefficients of the complex polynomial (5.10):
 $$\begin{eqnarray}\unicode[STIX]{x1D63D}=\left(\begin{array}{@{}rrrrrrrr@{}}a_{4} & -b_{4} & 0 & 0 & 0 & 0 & 0 & 0\\ b_{3} & a_{3} & a_{4} & -b_{4} & 0 & 0 & 0 & 0\\ -a_{2} & b_{2} & b_{3} & a_{3} & a_{4} & -b_{4} & 0 & 0\\ -b_{1} & -a_{1} & -a_{2} & b_{2} & b_{3} & a_{3} & a_{4} & -b_{4}\\ a_{0} & -b_{0} & -b_{1} & -a_{1} & -a_{2} & b_{2} & b_{3} & a_{3}\\ 0 & 0 & a_{0} & -b_{0} & -b_{1} & -a_{1} & -a_{2} & b_{2}\\ 0 & 0 & 0 & 0 & a_{0} & -b_{0} & -b_{1} & -a_{1}\\ 0 & 0 & 0 & 0 & 0 & 0 & a_{0} & -b_{0}\\ \end{array}\right).\end{eqnarray}$$
The necessary and sufficient condition for stability by Bilharz (Reference Bilharz1944) requires positiveness of the determinants of all four diagonal sub-matrices of even order of the matrix
 $\unicode[STIX]{x1D63D}$
,
 $$\begin{eqnarray}m_{1}=\det \left(\begin{array}{@{}cc@{}}a_{4} & -b_{4}\\ b_{3} & a_{3}\\ \end{array}\right)>0,\ \dots ,\ m_{4}=\det \unicode[STIX]{x1D63D}>0,\end{eqnarray}$$
in order that all the roots of the complex polynomial (5.10) have negative real parts (Kirillov Reference Kirillov2013). Although generally the Bilharz stability condition for the fourth-order complex polynomial consists of four separate criteria (6.2), it has been verified both numerically and analytically via analysis of the growth rates in Kirillov & Stefani (Reference Kirillov and Stefani2010, Reference Kirillov and Stefani2013) that it is the last one,
 $m_{4}>0$
, that determines stability for all cases considered.
The dispersion relation (5.9) and stability criteria (6.2) may look complicated at first glance. In order to familiarize the reader with them, we first demonstrate that they easily yield a number of classical results, see e.g. Acheson & Hide (Reference Acheson and Hide1973), Acheson (Reference Acheson1978) and Goedbloed, Keppens & Poedts (Reference Goedbloed, Keppens and Poedts2010).
In the ideal case with
 ${\it\omega}_{{\it\nu}}=0$
and
 ${\it\omega}_{{\it\eta}}=0$
the dispersion relation (5.9) takes the form
 $$\begin{eqnarray}\displaystyle p({\it\gamma}) & = & \displaystyle 4{\it\alpha}^{2}({\it\omega}_{A_{{\it\phi}}}^{2}\mathit{Rb}-{\rm\Omega}^{2}\mathit{Ro})\left((\text{i}{\it\gamma}-m{\rm\Omega})^{2}-(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})^{2}\right)\nonumber\\ \displaystyle & & \displaystyle -\,4{\it\alpha}^{2}\left({\rm\Omega}(\text{i}{\it\gamma}-m{\rm\Omega})+{\it\omega}_{A_{{\it\phi}}}(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})\right)^{2}\nonumber\\ \displaystyle & & \displaystyle +\,\left((\text{i}{\it\gamma}-m{\rm\Omega})^{2}-(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})^{2}\right)^{2}=0.\end{eqnarray}$$
At
 ${\it\alpha}=1$
this is exactly the dispersion relation by Ogilvie & Pringle (Reference Ogilvie and Pringle1996). At
 ${\it\omega}_{A_{{\it\phi}}}=0$
and
 $m=0$
this is the dispersion relation of SMRI by Balbus & Hawley (Reference Balbus and Hawley1992). At
 ${\it\omega}_{{\it\nu}}=0$
,
 ${\it\omega}_{{\it\eta}}=0$
,
 ${\it\omega}_{A_{z}}=0$
and
 ${\it\omega}_{A_{{\it\phi}}}=0$
the roots of the dispersion relation (5.9) are
 $$\begin{eqnarray}\displaystyle {\it\gamma}_{1,2}=-\text{i}m{\rm\Omega}\pm \text{i}2{\it\alpha}{\rm\Omega}\sqrt{1+\mathit{ Ro}},\quad {\it\gamma}_{3,4}=-\text{i}m{\rm\Omega}. & & \displaystyle\end{eqnarray}$$
At
 ${\it\omega}_{{\it\nu}}=0$
,
 ${\it\omega}_{{\it\eta}}=0$
,
 ${\it\omega}_{A_{z}}=0$
and
 ${\it\omega}_{A_{{\it\phi}}}^{2}\mathit{Rb}={\rm\Omega}^{2}\mathit{Ro}$
the roots are pure imaginary
 $$\begin{eqnarray}\displaystyle & {\it\gamma}_{1,2}=-\text{i}(m+{\it\alpha}){\rm\Omega}\pm \text{i}\sqrt{(m+{\it\alpha})^{2}{\it\omega}_{A_{{\it\phi}}}^{2}+{\it\alpha}^{2}({\rm\Omega}^{2}-{\it\omega}_{A_{{\it\phi}}}^{2})}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & {\it\gamma}_{3,4}=-\text{i}(m-{\it\alpha}){\rm\Omega}\pm \text{i}\sqrt{(m-{\it\alpha})^{2}{\it\omega}_{A_{{\it\phi}}}^{2}+{\it\alpha}^{2}({\rm\Omega}^{2}-{\it\omega}_{A_{{\it\phi}}}^{2})}. & \displaystyle\end{eqnarray}$$
In the dissipative case, the threshold for SMRI is given by the equation
 $m_{4}=0$
with
 ${\it\omega}_{A_{{\it\phi}}}=0$
. This yields the expression found in Kirillov & Stefani (Reference Kirillov and Stefani2012):
 $$\begin{eqnarray}\mathit{Ro}=-\frac{({\it\omega}_{A_{z}}^{2}+{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}})^{2}+4{\it\alpha}^{2}{\rm\Omega}^{2}{\it\omega}_{{\it\eta}}^{2}}{4{\it\alpha}^{2}{\rm\Omega}^{2}({\it\omega}_{A_{z}}^{2}+{\it\omega}_{{\it\eta}}^{2})}.\end{eqnarray}$$
When
 $\mathit{Ro}=0$
,
 ${\rm\Omega}=0$
and
 $m=0$
we get from the equation
 $m_{4}=0$
an instability condition that extends that of Chandrasekhar (Reference Chandrasekhar1961) (see also Rüdiger et al.
Reference Rüdiger, Gellert, Schultz and Hollerbach2010) to the dissipative case:
 $$\begin{eqnarray}\mathit{Rb}>\frac{({\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}+{\it\omega}_{A_{z}}^{2})^{2}-4{\it\alpha}^{2}{\it\omega}_{A_{z}}^{2}{\it\omega}_{A_{{\it\phi}}}^{2}}{4{\it\alpha}^{2}{\it\omega}_{A_{{\it\phi}}}^{2}({\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}+{\it\omega}_{A_{z}}^{2})}.\end{eqnarray}$$
On the other hand, under the assumption that
 ${\rm\Omega}=0$
and
 ${\it\omega}_{A_{z}}=0$
the dispersion relation (5.9) is a real polynomial. Hence, by setting its constant term to zero we determine the condition for a static instability:
 $$\begin{eqnarray}\mathit{Rb}>\frac{({\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}+m^{2}{\it\omega}_{A_{{\it\phi}}}^{2})^{2}-4{\it\alpha}^{2}m^{2}{\it\omega}_{A_{{\it\phi}}}^{4}}{4{\it\alpha}^{2}{\it\omega}_{A_{{\it\phi}}}^{2}({\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}+m^{2}{\it\omega}_{A_{{\it\phi}}}^{2})}.\end{eqnarray}$$
In the ideal case (6.9) reduces to the criterion of Ogilvie & Pringle (Reference Ogilvie and Pringle1996):
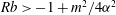 $\mathit{Rb}>-1+m^{2}/4{\it\alpha}^{2}$
. At
 $\mathit{Rb}=0$
the criterion (6.9) yields the standard Tayler (Reference Tayler1973) instability at
 $$\begin{eqnarray}{\it\omega}_{A_{{\it\phi}}}>\sqrt{\frac{{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}}{{\it\alpha}^{2}-(|m|-{\it\alpha})^{2}}}.\end{eqnarray}$$
Another particular case
 ${\it\omega}_{A_{z}}=0$
and
 $m=0$
yields the following extension of the stability condition by Michael (Reference Michael1954):
 $$\begin{eqnarray}\mathit{Ro}>-1+\mathit{Rb}\frac{{\it\omega}_{A_{{\it\phi}}}^{2}}{{\rm\Omega}^{2}}\frac{{\it\omega}_{{\it\nu}}}{{\it\omega}_{{\it\eta}}}-\frac{{\it\omega}_{{\it\nu}}^{2}}{4{\it\alpha}^{2}{\rm\Omega}^{2}}.\end{eqnarray}$$
Choosing, additionally,
 ${\it\omega}_{A_{{\it\phi}}}=0$
, we reproduce the result of Eckhardt & Yao (Reference Eckhardt and Yao1995):
 $$\begin{eqnarray}\displaystyle \mathit{Ro}>-1-\frac{{\it\omega}_{{\it\nu}}^{2}}{4{\it\alpha}^{2}{\rm\Omega}^{2}}. & & \displaystyle\end{eqnarray}$$
The ideal Michael criterion for stability of rotational flows in the presence of azimuthal magnetic fields with respect to axisymmetric perturbations
 $$\begin{eqnarray}\frac{\text{d}}{\text{d}R}({\rm\Omega}^{2}R^{4})-\frac{R^{4}}{{\it\rho}{\it\mu}_{0}}\frac{\text{d}}{\text{d}R}\left(\frac{B_{{\it\phi}}^{0}}{R}\right)^{2}>0\end{eqnarray}$$
or
 $$\begin{eqnarray}\mathit{Ro}>-1+\mathit{Rb}\frac{{\it\omega}_{A_{{\it\phi}}}^{2}}{{\rm\Omega}^{2}}\end{eqnarray}$$
follows from (6.11) when
 ${\it\omega}_{{\it\eta}}={\it\omega}_{{\it\nu}}$
and
 ${\it\omega}_{{\it\nu}}\rightarrow 0$
(see also Howard & Gupta Reference Howard and Gupta1962).
Finally, letting in (5.8)
 $$\begin{eqnarray}\mathit{Rb}=\mathit{Ro},\quad {\rm\Omega}={\it\omega}_{A_{{\it\phi}}}\end{eqnarray}$$
and assuming
 ${\it\omega}_{{\it\nu}}=0$
and
 ${\it\omega}_{{\it\eta}}=0$
, we find that the dispersion relation (5.9) has the roots
 $$\begin{eqnarray}\displaystyle {\it\gamma}_{1,2}=0,\quad {\it\gamma}_{3,4}=-2\text{i}{\it\omega}_{A_{{\it\phi}}}(m\pm {\it\alpha}), & & \displaystyle\end{eqnarray}$$
indicating marginal stability. Indeed, for an inviscid fluid of infinite electrical conductivity with
 $P=\text{const.}$
, conditions (6.15) define at
 $\mathit{Rb}=\mathit{Ro}=-1$
the Chandrasekhar equipartition solution – a special solution with the Alfvén angular velocity identical to the fluid angular velocity – which is marginally stable (Chandrasekhar Reference Chandrasekhar1956, Reference Chandrasekhar1961).
7. Dispersion relation in dimensionless parameters
The dispersion relation (5.9) with the matrix (5.8) has the same roots as the equation
 $$\begin{eqnarray}\det (\unicode[STIX]{x1D643}\unicode[STIX]{x1D64F}-{\it\gamma}\unicode[STIX]{x1D64F})=0,\end{eqnarray}$$
where
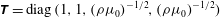 $\unicode[STIX]{x1D64F}=\text{diag}\,(1,1,({\it\rho}{\it\mu}_{0})^{-1/2},({\it\rho}{\it\mu}_{0})^{-1/2})$
. Let us change in (7.1) the spectral parameter to
 ${\it\gamma}=\widetilde{{\it\gamma}}\sqrt{{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}}$
and in addition to the hydrodynamic
 $(\mathit{Ro})$
and magnetic
 $(\mathit{Rb})$
Rossby numbers introduce the magnetic Prandtl number
 $(\mathit{Pm})$
, the ratio of the Alfvén frequencies
 $({\it\beta})$
, Reynolds
 $(\mathit{Re})$
and Hartmann
 $(\mathit{Ha})$
numbers, as well as the modified azimuthal wavenumber
 $n$
as follows:
 $$\begin{eqnarray}\mathit{Pm}=\frac{{\it\omega}_{{\it\nu}}}{{\it\omega}_{{\it\eta}}},\quad {\it\beta}={\it\alpha}\frac{{\it\omega}_{A_{{\it\phi}}}}{{\it\omega}_{A_{z}}},\quad \mathit{Re}={\it\alpha}\frac{{\rm\Omega}}{{\it\omega}_{{\it\nu}}},\quad \mathit{Ha}=\frac{{\it\omega}_{A_{z}}}{\sqrt{{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}}},\quad n=\frac{m}{{\it\alpha}}.\end{eqnarray}$$
Then, the dispersion relation (7.1) transforms into
 $$\begin{eqnarray}p(\widetilde{{\it\gamma}})=\det \left(\widetilde{\unicode[STIX]{x1D643}}-\frac{\widetilde{{\it\gamma}}}{\sqrt{\mathit{Pm}}}\unicode[STIX]{x1D644}\right)=0,\end{eqnarray}$$
with
 $$\begin{eqnarray}\widetilde{\unicode[STIX]{x1D643}}=\left(\begin{array}{@{}cccc@{}}-\text{i}n\mathit{Re}-1 & 2{\it\alpha}\mathit{Re} & \displaystyle \frac{\text{i}\mathit{Ha}(1+n{\it\beta})}{\sqrt{\mathit{Pm}}} & \displaystyle -\frac{2{\it\alpha}{\it\beta}\mathit{Ha}}{\sqrt{\mathit{Pm}}}\\ -\displaystyle \frac{2\mathit{Re}(1+\mathit{Ro})}{{\it\alpha}} & -\text{i}n\mathit{Re}-1 & \displaystyle \frac{2{\it\beta}\mathit{Ha}(1+\mathit{Rb})}{{\it\alpha}\sqrt{\mathit{Pm}}} & \displaystyle \frac{\text{i}\mathit{Ha}(1+n{\it\beta})}{\sqrt{\mathit{Pm}}}\\ \displaystyle \frac{\text{i}\mathit{Ha}(1+n{\it\beta})}{\sqrt{\mathit{Pm}}} & 0 & -\text{i}n\mathit{Re}-\displaystyle \frac{1}{\mathit{Pm}} & 0\\ \displaystyle \frac{-2{\it\beta}\mathit{HaRb}}{{\it\alpha}\sqrt{\mathit{Pm}}} & \displaystyle \frac{\text{i}\mathit{Ha}(1+n{\it\beta})}{\sqrt{\mathit{Pm}}} & \displaystyle \frac{2\mathit{ReRo}}{{\it\alpha}} & -\text{i}n\mathit{Re}-\displaystyle \frac{1}{\mathit{Pm}}\end{array}\right).\end{eqnarray}$$
The coefficients of the polynomial (7.3) are explicitly given by (B 2) in appendix B.
Next, we divide (7.3) by
 $\mathit{Re}$
and introduce the eigenvalue parameter
 $$\begin{eqnarray}{\it\lambda}=\frac{\widetilde{{\it\gamma}}}{\mathit{Re}\sqrt{\mathit{ Pm}}}=\frac{\widetilde{{\it\gamma}}\sqrt{{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}}}{{\it\alpha}{\rm\Omega}}=\frac{{\it\gamma}}{{\it\alpha}{\rm\Omega}}.\end{eqnarray}$$
This results in the dispersion relation
 $$\begin{eqnarray}p({\it\lambda})=\det (\unicode[STIX]{x1D648}-{\it\lambda}\unicode[STIX]{x1D644})=0,\end{eqnarray}$$
with (Kirillov & Stefani Reference Kirillov and Stefani2013)
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D648}=\left(\begin{array}{@{}cccc@{}}-\text{i}n-\displaystyle \frac{1}{\mathit{Re}} & 2{\it\alpha} & \text{i}(1+n{\it\beta})\displaystyle \sqrt{\frac{\mathit{ N }}{\mathit{Rm}}} & \displaystyle -2{\it\alpha}{\it\beta}\sqrt{\frac{\mathit{ N }}{\mathit{Rm}}}\\ -\displaystyle \frac{2(1+\mathit{Ro})}{{\it\alpha}} & \displaystyle -\text{i}n-\frac{1}{\mathit{Re}} & \displaystyle \frac{2{\it\beta}(1+\mathit{Rb})}{{\it\alpha}}\sqrt{\frac{\mathit{ N }}{\mathit{Rm}}} & \displaystyle \text{i}(1+n{\it\beta})\sqrt{\frac{\mathit{ N }}{\mathit{Rm}}}\\ \displaystyle \text{i}(1+n{\it\beta})\sqrt{\frac{\mathit{ N }}{\mathit{Rm }}} & 0 & \displaystyle -\text{i}n-\frac{1}{\mathit{Rm}} & 0\\ \displaystyle \frac{-2{\it\beta}\mathit{Rb}}{{\it\alpha}}\sqrt{\frac{\mathit{ N }}{\mathit{Rm}}} & \displaystyle \text{i}(1+n{\it\beta})\sqrt{\frac{\mathit{ N }}{\mathit{Rm}}} & \displaystyle \frac{2\mathit{Ro}}{{\it\alpha}} & -\text{i}n-\displaystyle \frac{1}{\mathit{Rm}}\end{array}\right). & & \displaystyle\end{eqnarray}$$
Here,
 $\mathit{N}=\mathit{Ha}^{2}/\mathit{Re}$
is the Elsasser number (interaction parameter) and
 $\mathit{Rm}=\mathit{Re}Pm$
is the magnetic Reynolds number. Explicit coefficients of the dispersion relation (7.6) can be found in (B 3) of appendix B. In the following, we will use the dispersion relations (5.9), (7.3), and (7.6) with different parameterizations in order to facilitate physical interpretation and comparison with the results obtained by the astrophysical, MHD, plasma physics and hydrodynamical communities.
8. Inductionless approximation
In this section, we focus on the inductionless approximation by setting the magnetic Prandtl number to zero (Hollerbach & Rüdiger Reference Hollerbach and Rüdiger2005; Priede Reference Priede2011) which is a reasonable approximation for liquid-metal experiments as well as for some colder parts of accretion disks.
8.1. The threshold of instability
Consider the dispersion relation (7.3). Substitute its coefficients (B 2) to the matrix
 $\unicode[STIX]{x1D63D}$
in (6.1) and then calculate the determinants
 $m_{i}$
according to (6.2). Set
 $\mathit{Pm}=0$
in the resulting expressions for
 $m_{i}$
. For the coefficient
 $m_{4}=\det \unicode[STIX]{x1D63D}$
this leads to a great simplification and yields the instability threshold in a compact and closed form:
 $$\begin{eqnarray}\frac{\mathit{Ha}^{4}{\it\beta}^{2}(n{\it\beta}+1)^{2}\mathit{Ro}^{2}-\left(C^{2}-4\mathit{ Ha}^{4}{\it\beta}^{2}(n{\it\beta}+1)^{2}\right)(\mathit{Ro}+1)}{(1+\mathit{ Ha}^{2}(n{\it\beta}+1)^{2})^{2}-4\mathit{Ha}^{2}{\it\beta}^{2}(1+\mathit{Ha}^{2}(n{\it\beta}+1)^{2})\mathit{ Rb}-4\mathit{Ha}^{4}{\it\beta}^{2}(n{\it\beta}+1)^{2}}=\frac{C^{2}}{4\mathit{Re}^{2}},\end{eqnarray}$$
where
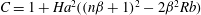 $C=1+\mathit{Ha}^{2}((n{\it\beta}+1)^{2}-2{\it\beta}^{2}\mathit{Rb})$
. Further on in the text we will also derive this threshold from the explicit expressions for the growth rate of the perturbation.
In the limit
 $\mathit{Re}\rightarrow \infty$
(8.1) reduces to a quadratic equation with respect to
 $\mathit{Ro}$
in the numerator of its left-hand side. Dividing this equation by
 $\mathit{Ha}^{4}$
and then letting
 $\mathit{Ha}\rightarrow \infty$
yields
 $$\begin{eqnarray}{\it\beta}^{2}(n{\it\beta}+1)^{2}\mathit{Ro}^{2}-(((n{\it\beta}+1)^{2}-2{\it\beta}^{2}\mathit{Rb})^{2}-4{\it\beta}^{2}(n{\it\beta}+1)^{2})(\mathit{Ro}+1)=0\end{eqnarray}$$
with the roots
 $$\begin{eqnarray}\displaystyle \mathit{Ro}^{\pm } & = & \displaystyle -2+\frac{(n{\it\beta}+1)^{2}-2{\it\beta}^{2}\mathit{ Rb}\pm \sqrt{((n{\it\beta}+1)^{2}-2{\it\beta}^{2}\mathit{ Rb })^{2}-4{\it\beta}^{2}(n{\it\beta}+1)^{2}}}{2{\it\beta}^{2}(n{\it\beta}+1)^{2}((n{\it\beta}+1)^{2}-2{\it\beta}^{2}\mathit{Rb})^{-1}}.\end{eqnarray}$$
At
 $n=0$
and
 $\mathit{Rb}=-1$
the expression (8.3) reduces to that of Kirillov & Stefani (Reference Kirillov and Stefani2011)
 $$\begin{eqnarray}\mathit{Ro}^{\pm }=\frac{4{\it\beta}^{4}+1\pm (2{\it\beta}^{2}+1)\sqrt{4{\it\beta}^{4}+1}}{2{\it\beta}^{2}}.\end{eqnarray}$$
From (8.4) one can find
 ${\it\beta}$
as a function of
 $\mathit{Ro}$
to recover the results of Priede (Reference Priede2011).
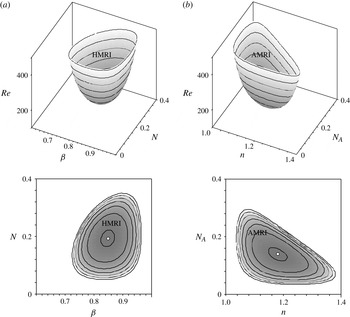
(a) The function
 $\mathit{Ro}^{-}({\it\beta},n)$
given by (8.3) at
 $\mathit{Rb}=-\frac{25}{32}$
. (b) Its extrema (8.6) along which the critical hydrodynamic Rossby number attains the maximal value
 $\mathit{ Ro}^{-}=-\frac{3}{4}$
. The cross-section of the function at (c)
 $n=0$
(HMRI) and (d) as
 ${\it\beta}\rightarrow +\infty$
(AMRI).

8.2. Extremal properties of the critical hydrodynamic Rossby number
For a given magnetic Rossby number,
 $\mathit{Rb}$
, the functions
 $\mathit{R}o^{\pm }(n,{\it\beta})$
take their extrema
 $$\begin{eqnarray}\mathit{Ro}_{extr}^{\pm }=-2-4\mathit{Rb}\pm 2\sqrt{2\mathit{Rb }(2\mathit{Rb }+1)}\end{eqnarray}$$
at the following extremal curves in the
 $(n,{\it\beta})$
-plane (cf. Kirillov et al.
Reference Kirillov, Stefani and Fukumoto2012):
 $$\begin{eqnarray}{\it\beta}_{extr}^{+}=\frac{-1}{n+\sqrt{-2\mathit{Rb}}},\quad {\it\beta}_{extr}^{-}=\frac{-1}{n-\sqrt{-2\mathit{Rb}}},\end{eqnarray}$$
see figure 1(b). The branch
 $\mathit{Ro}^{-}({\it\beta},n)$
is shown in figure 1(a) for
 $\mathit{Rb}=-\frac{25}{32}$
(this particular value has been chosen since it is the minimum value which leads to destabilization of Keplerian profiles, as we will see below). The maximal value of the hydrodynamic Rossby number is constant along the curves (8.6), see figure 1(a,b).
The cross-section of the function
 $\mathit{Ro}^{-}({\it\beta},n)$
at
 $n=0$
corresponding to the helical magnetorotational instability (HMRI) is plotted in figure 1(c). In contrast, figure 1(d) shows the limit
 ${\it\beta}\rightarrow +\infty$
 $$\begin{eqnarray}\mathit{Ro}^{-}(n,\mathit{Rb})=-2+(n^{2}-2\mathit{Rb})\frac{n^{2}-2\mathit{Rb}-\sqrt{(n^{2}-2\mathit{Rb })^{2}-4n^{2}}}{2n^{2}}\end{eqnarray}$$
corresponding to the azimuthal magnetorotational instability (AMRI).
The function (8.7) attains its maximal value
 $\mathit{Ro}_{extr}^{-}$
given by (8.5) at
 $$\begin{eqnarray}n=\pm \sqrt{-2\mathit{Rb}}.\end{eqnarray}$$
Since by definition (7.2)
 $n=m/{\it\alpha}$
where
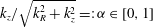 $k_{z}/\sqrt{k_{R}^{2}+k_{z}^{2}}=:{\it\alpha}\in [0,1]$
, then for
 $\mathit{ Rb}\in [-1,-0.5]$
the condition (8.8) yields the only possible integer values of the azimuthal wavenumber:
 $$\begin{eqnarray}\displaystyle m=\pm 1. & & \displaystyle\end{eqnarray}$$
This means that the effect of the purely azimuthal magnetic field is most pronounced at the maximal possible range of variation of the hydrodynamic Rossby number for the lowest azimuthal modes with
 $m=\pm 1$
(Hollerbach et al.
Reference Hollerbach, Teeluck and Rüdiger2010; Kirillov, Stefani & Fukumoto Reference Kirillov, Stefani and Fukumoto2014).
8.3. A band structure periodic in
 ${\it\alpha}$

What is the general dependence of the mode number
 $m$
on
 ${\it\alpha}$
,
 $\mathit{ Rb}$
and the ratio
 ${\it\omega}_{A_{{\it\phi}}}/{\it\omega}_{A_{z}}$
of the azimuthal to the axial magnetic fields? Let us express
 ${\it\alpha}$
from (8.6) as
 $$\begin{eqnarray}{\it\alpha}=\pm \left(m+\frac{{\it\omega}_{A_{z}}}{{\it\omega}_{A_{{\it\phi}}}}\right)\frac{1}{\sqrt{-2\mathit{Rb}}}.\end{eqnarray}$$
The ratio
 ${\it\omega}_{A_{{\it\phi}}}/{\it\omega}_{A_{z}}$
when plotted against
 ${\it\alpha}$
at different
 $m$
and
 $\mathit{Rb}$
uncovers a regular pattern shown in figure 2. The pattern is periodic in
 ${\it\alpha}$
with the period
 $1/\sqrt{-2\mathit{Rb}}$
. On the other hand, the dependence of
 ${\it\alpha}$
on the ratio of the magnetic fields is a continuous piecewise smooth function inside every vertical ‘band’ with the width
 $1/(2\sqrt{-2\mathit{ Rb}})$
in
 ${\it\alpha}$
, see figure 2(b). The vertical bands in figure 2 are further separated into cells with the boundaries at
 $$\begin{eqnarray}\frac{{\it\omega}_{A_{{\it\phi}}}}{{\it\omega}_{A_{z}}}=\frac{2}{1},\frac{2}{2},\frac{2}{3},\frac{2}{4},\frac{2}{5},\frac{2}{6},\dots .\end{eqnarray}$$
Every particular cell in figure 2 corresponds to a unique integer azimuthal wavenumber
 $m$
. Note however that the cells with the same
 $m$
are grouped along the same hyperbolic curve given by (8.10).
The periodic-in-
 ${\it\alpha}$
band structure at (a)
 $\mathit{Rb}=-1$
(with grey cells corresponding to
 $m=-2$
) and (b)
 $\mathit{Rb}=-0.5$
(with the grey stripe marking the first band).

The curves (8.10) with slopes of the same sign do not cross. The crossings of two hyperbolic curves (8.10) with the integer indices
 $m_{1}$
and
 $m_{2}$
and slopes of different sign happen at
 $$\begin{eqnarray}{\it\alpha}=\frac{m_{1}-m_{2}}{2\sqrt{-2\mathit{Rb}}}\quad \text{and}\quad \frac{{\it\omega}_{A_{{\it\phi}}}}{{\it\omega}_{A_{z}}}=\frac{-2}{m_{1}+m_{2}},\end{eqnarray}$$
which explains the sequence (8.11). Within one and the same band with
 ${\it\alpha}\geqslant 0$
the cells are encoded by two interlacing series of integers, e.g. for the third band in figure 2(a)
 $$\begin{eqnarray}m=+1,-2,0,-3,-1,-4,-2,-5,-3,-6,\dots ,\end{eqnarray}$$
which is a mixture of the sequences
 $$\begin{eqnarray}\displaystyle +1,0,-1,-2,-3,\dots \quad \text{and}\quad -2,-3,-4,-5,-6,\dots , & & \displaystyle\end{eqnarray}$$
whereas for the second band with
 ${\it\alpha}\geqslant 0$
in figure 2(a) we have
 $$\begin{eqnarray}m=-1,0,-2,-1,-3,-2,-4,-3,-5,-4,\dots ,\end{eqnarray}$$
which corresponds to the two interlacing sequences
 $$\begin{eqnarray}-1,-2,-3,-4,-5,\dots \quad \text{and}\quad 0,-1,-2,-3,-4,\dots .\end{eqnarray}$$
Therefore, at the crossings (8.12) with
 ${\it\alpha}\neq 0$
the quadruplet of cells consists of two pairs; each pair corresponding to a different value of the azimuthal wavenumber
 $m$
. At the crossings with
 ${\it\alpha}=0$
all four cells in the quadruplet have the same
 $m$
.
(a) The lower (LLL) and the upper (ULL) Liu limits existing at
 $\mathit{Rb}=-1$
are points on the quasi-hyperbolic curve (8.20) in the
 $\mathit{Ro}{-}\mathit{Rb}$
plane. (b) A scaled fragment of the limiting curve (8.18) demonstrating that the inductionless forms of the magnetorotational instability exist above the lower Liu limit
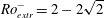 $\mathit{Ro}_{extr}^{-}=2-2\sqrt{2}$
when
 $\mathit{Rb}>-\frac{25}{32}$
. The open circle marks the Keplerian value for the Rossby number
 $\text{Ro}=-\frac{3}{4}$
at
 $\mathit{Rb}=-\frac{25}{32}$
whereas the black circle corresponds to
 $\mathit{Ro}=\mathit{Rb}=-\frac{2}{3}$
. The dashed diagonal is given by the equation
 $\mathit{Ro}=\mathit{Rb}$
.

8.4. Continuation of the Liu limits to arbitrary
$\mathit{Rb}$

The extrema (8.5) can be represented in the form
 $$\begin{eqnarray}\mathit{Ro}_{extr}^{\pm }=-1-\left(\sqrt{2\mathit{Rb}}\mp \sqrt{1+2\mathit{Rb}}\right)^{2},\end{eqnarray}$$
which is equivalent to the expression
 $$\begin{eqnarray}\mathit{Rb}=-\frac{1}{8}\frac{(\mathit{Ro}+2)^{2}}{\mathit{Ro}+1}\end{eqnarray}$$
that is universal in the sense that it contains only logarithmic derivatives of the radial profiles of the flow and the azimuthal field.
The particular case of (8.18) at
 $\mathit{Rb}=-1$
yields the result of Liu et al. (Reference Liu, Goodman, Herron and Ji2006), also reproduced by Kirillov & Stefani (Reference Kirillov and Stefani2011) and Priede (Reference Priede2011). Solving (8.18) at
 $\mathit{Rb}=-1$
, we find that the critical Rossby numbers
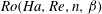 $\mathit{Ro}(\mathit{Ha},\mathit{Re},n,{\it\beta})$
given by (8.1), and thus the instability domains, lie at
 $\mathit{Pm}=0$
and
 $\mathit{Rb}=-1$
outside the stratum
 $$\begin{eqnarray}\displaystyle 2-2\sqrt{2}=:\mathit{Ro}_{LLL}<\mathit{Ro}(\mathit{Ha},\mathit{Re},n,{\it\beta})<\mathit{Ro}_{ULL}:=2+2\sqrt{2}, & & \displaystyle\end{eqnarray}$$
where
 $\mathit{Ro}_{LLL}$
is the value of
 $\mathit{Ro}_{extr}^{-}$
at the lower Liu limit (LLL) and
 $\mathit{Ro}_{ULL}$
is the value of
 $\mathit{Ro}_{extr}^{+}$
at the upper Liu limit (ULL) corresponding to the critical values of
 ${\it\beta}$
given by (8.6).
Figure 3(a) shows how the LLL and ULL continue to the values of
 $\mathit{Rb}\neq -1$
. In fact, the LLL and the ULL are points on the quasi-hyperbolic curve
 $$\begin{eqnarray}(\mathit{Rb}-\mathit{Ro}-1)^{2}-(\mathit{Rb}+\mathit{Ro}+1)^{2}={\textstyle \frac{1}{2}}(\mathit{Ro}+2)^{2},\end{eqnarray}$$
which is another representation of (8.18). At
 $\mathit{ Rb}=-\frac{1}{2}$
the branches
 $\mathit{Ro}_{extr}^{-}(\mathit{Rb})$
and
 $\mathit{ Ro}_{extr}^{+}(\mathit{Rb})$
meet each other. Therefore, the inductionless magnetorotational instability at negative
 $\mathit{Rb}$
also exists at positive
 $\mathit{Ro}$
when
 $\mathit{Ro}>\mathit{Ro}_{extr}^{+}(\mathit{Rb})$
, figure 3(a). Notice also the second stability domain at
 $\mathit{Rb}>0$
and
 $\mathit{Ro}<-1$
.
We see that in the inductionless case
 $\mathit{Pm}=0$
when the Reynolds and Hartmann numbers subsequently tend to infinity as described in § 8.1 and
 ${\it\beta}$
and
 $n$
are under the constraints (8.6), the maximal possible critical Rossby number
 $\mathit{Ro}_{extr}^{-}$
increases with the increase of
 $\mathit{Rb}$
. At
 $$\begin{eqnarray}\mathit{Rb}\geqslant -{\textstyle \frac{25}{32}}=-0.78125\end{eqnarray}$$
 $\mathit{Ro}_{extr}^{-}(\mathit{Rb})$
exceeds the critical value for the Keplerian flow:
 $\mathit{Ro}_{extr}^{-}\geqslant -\frac{3}{4}$
.
Therefore, the possibility for
 $B_{{\it\phi}}(R)$
to depart from the profile
 $B_{{\it\phi}}(R)\propto R^{-1}$
allows us to break the conventional lower Liu limit and extend the inductionless versions of MRI to the velocity profiles
 ${\rm\Omega}(R)$
as flat as the Keplerian one and even to less steep profiles, including that of the solid body rotation, i.e.
 $\mathit{ Ro}=0$
, for
 $\mathit{Rb}\geqslant -\frac{1}{2}$
, figure 3(b).
Domains of the inductionless HMRI for
 $\mathit{Pm}=0$
,
 $n=0$
, and
 $\mathit{Rb}=-0.74$
when the Hartmann and Reynolds numbers follow the scaling law (8.22) with
 ${\it\beta}$
satisfying the restraints (8.6): (a)
 $\mathit{Ha}=5$
and
 $\mathit{Re}\approx 92$
; (b)
 $\mathit{Ha}=100$
and
 $\mathit{ Re}\approx 736\,158$
. With the increase in
 $\mathit{Ha}$
and
 $\mathit{Re}$
the HMRI domain easily breaks the conventional Liu limits as well as the Kepler line
 $\mathit{Ro}=-0.75$
and its boundary tends to the curves (8.3) that touch the new limits for the critical Rossby number:
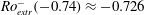 $\mathit{Ro}_{extr}^{-}(-0.74)\approx -0.726$
and
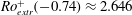 $\mathit{Ro}_{extr}^{+}(-0.74)\approx 2.646$
.

8.5. Scaling law of the inductionless MRI
What asymptotic behaviour of the Reynolds and Hartmann numbers at infinity leads to maximization of negative (and simultaneously to minimization of positive) critical Rossby numbers? To get an idea, we investigate extrema of
 $\mathit{Ro}$
as a solution to (8.1) subject to the constraints (8.6). Taking e.g.
 ${\it\beta}={\it\beta}_{extr}^{-}$
in (8.1), differentiating the result with respect to
 $\mathit{Ha}$
, equating it to zero and solving the equation for
 $\mathit{Re}$
, we find the following asymptotic relation between
 $\mathit{Ha}$
and
 $\mathit{Re}$
when
 $\mathit{Ha}\rightarrow \infty$
:
 $$\begin{eqnarray}\mathit{Re}=2\mathit{Rb}\sqrt{3\mathit{Rb }+2}(\sqrt{1+2\mathit{Rb}}+\sqrt{2\mathit{Rb}}){\it\beta}^{3}\mathit{Ha}^{3}+O(\mathit{Ha}).\end{eqnarray}$$
For example, at
 $\mathit{Rb}=-1$
and
 $n=0$
we have
 ${\it\beta}={\it\beta}_{extr}^{-}=\frac{1}{\sqrt{2}}$
. After taking this into account in (8.22) we obtain the scaling law of HMRI found in Kirillov & Stefani (Reference Kirillov and Stefani2010):
 $$\begin{eqnarray}\mathit{Re}=\frac{2+\sqrt{2}}{2}\mathit{Ha}^{3}+O(\mathit{Ha}).\end{eqnarray}$$
Figure 4 shows the domains of the inductionless helical MRI at
 $\mathit{Rb}=-0.74$
when the Hartmann and the Reynolds numbers are increasing in accordance with the scaling law (8.22). The instability thresholds easily penetrate the LLL and ULL as well as the Keplerian line and tend to the curves (8.3) that touch the new limits for the critical Rossby number:
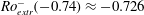 $\mathit{Ro}_{extr}^{-}(-0.74)\approx -0.726$
and
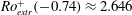 $\mathit{Ro}_{extr}^{+}(-0.74)\approx 2.646$
. Note that the curves (8.3) also correspond to the limit of vanishing Elsasser number
 $\mathit{N}$
, because according to the scaling law (8.22) we have
 $\mathit{ N}\propto 1/\mathit{Ha}$
as
 $\mathit{Ha}\rightarrow \infty$
. This observation makes the dispersion relation (7.6) advantageous for investigation of the inductionless versions of MRI.
8.6. Growth rates of HMRI and AMRI and the critical Reynolds number
We will calculate the growth rates of the inductionless MRI with the use of the dispersion relation (7.6). Assuming in (7.6)
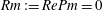 $\mathit{ Rm}:=\mathit{Re}\mathit{Pm}=0$
, we find the roots explicitly:
 $$\begin{eqnarray}{\it\lambda}_{1,2}=-\text{i}n+\mathit{N}\left(2{\it\beta}^{2}\mathit{Rb}-(n{\it\beta}+1)^{2}\right)-\frac{1}{\mathit{Re}}\pm 2\sqrt{X+\text{i}Y},\end{eqnarray}$$
where
 $$\begin{eqnarray}X=\mathit{N}^{2}{\it\beta}^{2}\left({\it\beta}^{2}\mathit{Rb}^{2}+(n{\it\beta}+1)^{2}\right)-\mathit{Ro}-1,\quad Y=\mathit{N}{\it\beta}(\mathit{Ro}+2)(n{\it\beta}+1).\end{eqnarray}$$
Separating the real and imaginary parts of the roots, we find the growth rates of the inductionless MRI in closed form:
 $$\begin{eqnarray}({\it\lambda}_{1,2})_{r}=\mathit{N}\left(2{\it\beta}^{2}\mathit{Rb}-(n{\it\beta}+1)^{2}\right)-\frac{1}{\mathit{Re}}\pm \sqrt{2X+2\sqrt{X^{2}+Y^{2}}}.\end{eqnarray}$$
Particularly, at
 $n=0$
we obtain the growth rates of the axisymmetric helical magnetorotational instability in the inductionless case.
Introducing the Elsasser number of the azimuthal field as
 $$\begin{eqnarray}\mathit{N}_{A}:={\it\beta}^{2}\mathit{N}\end{eqnarray}$$
and then taking the limit of
 ${\it\beta}\rightarrow \infty$
we obtain from (8.26) the growth rates of the inductionless azimuthal MRI:
 $$\begin{eqnarray}\displaystyle & & \displaystyle ({\it\lambda}_{1,2})_{r}=\mathit{N}_{A}(2\mathit{Rb}-n^{2})-\frac{1}{\mathit{Re}}\pm \sqrt{2}\nonumber\\ \displaystyle & & \displaystyle \quad \times \,\sqrt{\mathit{N }_{A}^{2}(\mathit{Rb }^{2}+n^{2})-\mathit{ Ro }-1+\sqrt{\left(\mathit{N }_{A}^{2}(\mathit{Rb }^{2}+n^{2})-\mathit{ Ro }-1\right)^{2}+\mathit{ N }_{A}^{2}(\mathit{Ro }+2)^{2}n^{2}}}.\end{eqnarray}$$
In the inviscid limit
 $\mathit{Re}\rightarrow \infty$
the term
 $1/\mathit{Re}$
vanishes in the expressions (8.26) and (8.28).
Domain of the viscous inductionless MRI (8.29) of a Keplerian flow (
 $\mathit{Ro}=-0.75$
) at
 $\mathit{Rb}=-0.75$
when (a)
 $n=0$
(axisymmetric HMRI) and (b)
 ${\it\beta}\rightarrow \infty$
(non-axisymmetric AMRI). Open circles mark the location of the minima of the critical hydrodynamic Reynolds number: (a)
 ${\it\beta}\approx 0.848$
,
 $\mathit{N}\approx 0.193$
,
 $\mathit{Re}\approx 198.5$
; (b)
 $n\approx 1.180$
,
 $\mathit{ N}_{A}\approx 0.139$
,
 $\mathit{Re}\approx 198.5$
.

On the other hand, in the viscous case the condition
 $({\it\lambda}_{1,2})_{r}>0$
yields the critical hydrodynamic Reynolds number beyond which inductionless MRI appears. For example, from (8.26) we find the following criterion for the onset of the instability:
 $$\begin{eqnarray}\mathit{Re}>\frac{1}{\mathit{N}\left(2{\it\beta}^{2}\mathit{Rb}-(n{\it\beta}+1)^{2}\right)+\sqrt{2X+2\sqrt{X^{2}+Y^{2}}}}.\end{eqnarray}$$
With
 $n=0$
the criterion (8.29) corresponds to the axisymmetric HMRI. A similar criterion for the onset of AMRI follows from (8.28).
The critical hydrodynamic Reynolds number for a Keplerian flow at
 $\mathit{ Rb}=-0.75$
is plotted in figure 5 as a function of the Elsasser number and (figure 5
a)
 ${\it\beta}$
in case of the axisymmetric HMRI and (figure 5
b)
 $n$
in case of the non-axisymmetric AMRI. In both cases the minimal
 $\mathit{Re}$
at the onset of instability is about
 $200$
.
 $\mathit{Ro}=-0.75$
. (a) The growth rates
 ${\it\lambda}_{r}\geqslant 0$
of viscous (
 $\mathit{Re}=800$
) HMRI (
 $n=0$
) in the inductionless
 $(\mathit{Pm}=0)$
limit in projection onto the
 $\mathit{N}{-}{\it\beta}$
plane. (b) The same in the inviscid
 $(\mathit{Re}\rightarrow \infty )$
limit. (c) The growth rates
 ${\it\lambda}_{r}\geqslant 0$
of AMRI (
 ${\it\beta}\rightarrow \infty$
) in the inductionless and inviscid limit in projection onto the
 $\mathit{N}_{A}{-}n$
plane. The open circles mark the maxima of
 ${\it\lambda}_{r}$
. Row (a) (left to right):
 ${\it\beta}\approx 0.830$
,
 $\mathit{N}\approx 0.153$
,
 ${\it\lambda}_{r}\approx 0.002$
;
 ${\it\beta}\approx 0.848$
,
 $\mathit{N}\approx 0.193$
,
 ${\it\lambda}_{r}\approx 0.004$
;
 ${\it\beta}\approx 0.869$
,
 $\mathit{N}\approx 0.236$
,
 ${\it\lambda}_{r}\approx 0.007$
. Row (b):
 ${\it\beta}\approx 0.830$
,
 $\mathit{ N}\approx 0.153$
,
 ${\it\lambda}_{r}\approx 0.003$
;
 ${\it\beta}\approx 0.848$
,
 $\mathit{N}\approx 0.193$
,
 ${\it\lambda}_{r}\approx 0.005$
;
 ${\it\beta}\approx 0.869$
,
 $\mathit{N}\approx 0.236$
,
 ${\it\lambda}_{r}\approx 0.008$
. Row (c):
 $n\approx 1.204$
,
 $\mathit{N}_{A}\approx 0.105$
,
 ${\it\lambda}_{r}\approx 0.003$
;
 $n\approx 1.180$
,
 $\mathit{N}_{A}\approx 0.139$
,
 ${\it\lambda}_{r}\approx 0.005$
;
 $n\approx 1.151$
,
 $\mathit{N}_{A}\approx 0.178$
,
 ${\it\lambda}_{r}\approx 0.008$
.

8.7. HMRI and AMRI as magnetically destabilized inertial waves
Consider the Taylor expansion of the eigenvalues (8.24) with respect to the Elsasser number
 $\mathit{N}$
in the vicinity of
 $\mathit{N}=0$
:
 $$\begin{eqnarray}\displaystyle \displaystyle {\it\lambda}_{1,2} & = & \displaystyle -\text{i}(n\mp 2\sqrt{\mathit{Ro }+1})-\frac{1}{\mathit{Re}}\nonumber\\ \displaystyle & & \displaystyle +\,\displaystyle \mathit{N}\left(-(n{\it\beta}+1)^{2}+2{\it\beta}^{2}\mathit{Rb}\pm {\it\beta}\frac{(\mathit{Ro}+2)}{\sqrt{\mathit{Ro }+1}}(n{\it\beta}+1)\right)+O(\mathit{N}^{2}).\end{eqnarray}$$
Expressions (8.24) and (8.30) generalize the result of Priede (Reference Priede2011) to the case of arbitrary
 $n$
,
 $\mathit{Re}$
and
 $\mathit{Rb}$
and exactly coincide with it at
 $n=0$
,
 $\mathit{Re}\rightarrow \infty$
and
 $\mathit{Rb}=-1$
.
In the absence of the magnetic field (
 $\mathit{N}=0$
) the eigenvalues
 ${\it\lambda}_{1,2}$
correspond to damped inertial (or Kelvin) waves. According to (8.29) at finite
 $\mathit{Re}$
there exists a critical finite
 $\mathit{N}>0$
that is necessary to trigger destabilization of the inertial waves by the magnetic field, see figures 5 and 6(a). However, as the expansion (8.30) demonstrates, in the limit
 $\mathit{Re}\rightarrow \infty$
the inductionless magnetorotational instability occurs when the effect of the magnetic field is much weaker than that of the flow – even when the Elsasser number is infinitesimally small, figure 6(b,c).
In the inviscid case the boundary of the domain of instability (8.29) takes the form
 $$\begin{eqnarray}\mathit{N}=\pm 2\sqrt{\frac{{\it\beta}^{2}(\mathit{Ro }+2)^{2}(n{\it\beta}+1)^{2}-((n{\it\beta}+1)^{2}-2{\it\beta}^{2}\mathit{ Rb })^{2}(\mathit{Ro }+1)}{((n{\it\beta}+1)^{2}-4{\it\beta}^{2}(\mathit{Rb}+1))((n{\it\beta}+1)^{2}-2{\it\beta}^{2}\mathit{Rb})^{2}(n{\it\beta}+1)^{2}}}.\end{eqnarray}$$
The lines (8.31) bound the domain of non-negative growth rates of HMRI in figure 6(b).
When
 $\mathit{Ro}=\mathit{Rb}$
, the stability boundary (8.31) has a self-intersection at
 $$\begin{eqnarray}n=-\frac{1}{{\it\beta}}\pm 2\sqrt{\mathit{Rb }+1},\quad \mathit{N}=\frac{\pm 1}{2{\it\beta}^{2}}\sqrt{\frac{-(3\mathit{Rb }+2)}{(\mathit{Rb}+1)(\mathit{Rb}+2)}}.\end{eqnarray}$$
For example, when
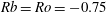 $\mathit{Rb}=\mathit{Ro}=-0.75$
and
 $n=0$
, the intersection happens at
 ${\it\beta}=1$
and
 $\mathit{N}=\frac{\sqrt{5}}{5}$
, figure 6(b). If
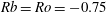 $\mathit{Rb}=\mathit{Ro}=-0.75$
and
 ${\it\beta}\rightarrow \infty$
, the intersection point is at
 $n=1$
and
 $\mathit{N}_{A}=\frac{\sqrt{5}}{5}$
, figure 6(c). In general, the intersection exists at
 $\mathit{N}\neq 0$
for
 $$\begin{eqnarray}\mathit{Ro}=\mathit{Rb}<-{\textstyle \frac{2}{3}}.\end{eqnarray}$$
At
 $\mathit{Ro}=\mathit{Rb}=-\frac{2}{3}$
the intersection occurs at
 $\mathit{N}=0$
.
In figure 6 we see that when
 $\mathit{Ro}<-\frac{2}{3}$
and
 $\mathit{ Ro}>\mathit{Rb}$
, the instability domain consists of two separate regions. In the case when
 $\mathit{Ro}<-\frac{2}{3}$
and
 $\mathit{Ro}<\mathit{Rb}$
, the two regions merge into one. When the condition (8.33) is fulfilled, the two sub-domains touch each other at the point (8.32). At
 $\mathit{ Ro}=\mathit{Rb}=-\frac{2}{3}$
the lower region shrinks to a single point which simultaneously is the intersection point (8.32) with
 $\mathit{ N}=0$
.
On the other hand, given
 $\mathit{Ro}<-\frac{2}{3}$
and decreasing
 $\mathit{Rb}$
we find that the single instability domain tends to split into two independent regions after crossing the line
 $\mathit{Ro}=\mathit{Rb}$
. The further decrease in
 $\mathit{Rb}$
yields diminishing size of the lower instability region, see figure 6. At which
 $\mathit{Rb}$
does the lower instability region completely disappear?
Clearly, the lower region disappears when the roots of the equation
 $\mathit{N}(n)=0$
become complex. From (8.31) we derive
 $$\begin{eqnarray}(n{\it\beta}+1)^{2}\pm {\it\beta}\frac{\mathit{Ro}+2}{\sqrt{\mathit{Ro }+1}}(n{\it\beta}+1)-2{\it\beta}^{2}\mathit{Rb}=0.\end{eqnarray}$$
The equations (8.34) have the roots
 $n$
complex if and only if their discriminant is negative:
 $$\begin{eqnarray}\frac{(\mathit{Ro}+2)^{2}}{\mathit{Ro}+1}+8\mathit{Rb}<0,\end{eqnarray}$$
which is simply the domain with the boundary given by the curve connecting the two Liu limits (8.18) that is shown in figure 3. Note that
 $\mathit{Rb}=-\frac{2}{3}$
and
 $\mathit{Ro}=-\frac{2}{3}$
satisfy (8.18), which indicates that the line
 $\mathit{Ro}=\mathit{Rb}$
is tangent to the curve (8.18) at the point
 $(-\frac{2}{3},-\frac{2}{3})$
in the
 $\mathit{ Ro}$
–
 $\mathit{Rb}$
plane, see figure 3(b).
Finally, we notice that the left-hand side of (8.34) is precisely the coefficient at
 $\mathit{N}$
in the expansion (8.30). In the inviscid case it determines the limit of the stability boundary as
 $\mathit{N}\rightarrow 0$
, quite in accordance with the scaling law (8.22). Solving (8.34) for
 $\mathit{Ro}$
, we exactly reproduce the formula (8.3). At
 $n=0$
and
 $\mathit{Rb}=-1$
equation (8.34) exactly coincides with that obtained by Priede (Reference Priede2011).
9. HMRI and AMRI at very small but finite
$\mathit{Pm}$

An advantage of the inductionless limit discussed above is the considerable simplification of dispersion relations at
 $\mathit{Pm}=0$
or
 $\mathit{Rm}=0$
that yields expressions for growth rates and stability criteria in explicit and closed form. There are, however, real physical situations that are characterized by small but finite values of the magnetic Reynolds and Prandtl numbers. Below, we demonstrate numerically that HMRI and AMRI also exist when
 $\mathit{Pm}\neq 0$
or
 $\mathit{ Rm}\neq 0$
. The pattern of the stability domains keeps the structure that we have found in the inductionless case. Moreover, the instability criteria of the inductionless limit serve as rather accurate guides in the physically more realistic situation of finite, but very small,
 $\mathit{Pm}$
.
9.1. Islands of HMRI at various integer
$n$
and their reconnection

Consider the dispersion relation (7.3) and substitute its coefficients (B 2) into the Bilharz matrix (6.1). Applying the Bilharz criterion (6.2) to the result, we find that it is the condition of vanishing the determinant of the Bilharz matrix that determines the instability threshold. Fixing the Rossby number at the Keplerian value
 $\mathit{Ro}=-0.75$
and assuming some reasonable values for the Hartmann and Reynolds numbers, e.g.
 $\mathit{Ha}=30$
and
 $\mathit{ Re}=40\,000$
, we choose the magnetic Rossby number slightly to the right of the line
 $\mathit{Ro}=\mathit{Rb}$
, which according to the criterion (8.21) should result in instability, at least in the inductionless case. For various integer modified azimuthal wavenumbers
 $n$
we plot the instability domains in the
 ${\it\beta}{-}\mathit{Pm}$
plane, figure 7(a,b).
 $\mathit{Ha}=30$
,
 $\mathit{Ro}=-0.75$
,
 $\mathit{Re}=40\,000$
,
 $\mathit{ Rb}=-0.755$
. (a,b) Islands of low-
 $\mathit{Pm}$
magnetorotational instability (axisymmetric HMRI with
 $n=0$
, non-axisymmetric HMRI with
 $n\neq 0,+1$
at
 ${\it\beta}\leqslant 2$
and AMRI with
 $n=+1$
at
 ${\it\beta}>2$
) corresponding to different modified azimuthal wavenumbers
 $n$
. (c,d) The growth rates
 ${\it\lambda}_{r}$
of the perturbation: (c) as functions of
 ${\it\beta}$
at
 $\mathit{Pm}=4\times 10^{-6}$
and different
 $n$
and (d) as functions of
 $\mathit{Pm}$
at different
 $n$
and
 ${\it\beta}$
.

Subsequently reconnecting instability islands at
 $\mathit{Ha}=30$
,
 $\mathit{Ro}=-0.75$
,
 $\mathit{Re}=40\,000$
and growing
 $\mathit{Rb}>-0.75$
: (a)
 $\mathit{Rb}=-0.74933$
, (b)
 $\mathit{Rb}=-0.747$
, and (c)
 $\mathit{Rb}=-0.742$
.

We see that at every integer
 $n$
there are several instability islands (curiously resembling those originating in a pure hydrodynamical Taylor–Couette problem Altmeyer et al. (Reference Altmeyer, Hoffmann and Lücke2011)). As is visible in figure 7(b) they tend to group into two clusters.
The first cluster consists of the islands situated at
 $\mathit{ Pm}<10^{-5}$
and contains intervals of the positive
 ${\it\beta}$
-axis at all
 $n$
but
 $n=+1$
, figure 7(a). Note that the modified azimuthal wavenumber
 $n$
corresponding to these islands follows exactly the sequence (8.13) that we have found in the inductionless case! The growth rates, i.e. the real parts of the roots
 ${\it\lambda}$
defined via relations (7.5), are plotted in figure 7(c) for a fixed value of
 $\mathit{Pm}$
that cuts this cluster along a vertical line. Figure 7(d) demonstrates the growth rates at various
 ${\it\beta}$
corresponding to particular values of
 $n$
. We see that for all
 $n$
but
 $n=+1$
the growth rates tend to some positive values as
 $\mathit{ Pm}\rightarrow 0$
indicating a smooth transition to the inductionless magnetorotational instabilities that occur both for axisymmetric (
 $n=0$
) and non-axisymmetric (
 $n\neq 0$
) perturbations. This seems to be the main reason for the manifestation of the sequence (8.13) in the pattern of the instability islands of figure 7(c).
The second cluster of instability islands occupies the region at
 $\mathit{Pm}>10^{-5}$
and is encoded by the sequence (8.15), see figure 7(b). We see that the islands of the two clusters tend to form quadruplets. Each quadruplet consists of the two pairs of islands corresponding to the indices
 $n$
that differ by 2, for example: 0 and
 $-2$
,
 $-1$
and
 $-3$
,
 $-2$
and
 $-4$
etc. Each quadruplet whose pairs are labelled with the indices
 $n_{i},n_{j}\leqslant 0$
tends to be centred at
 ${\it\beta}={\it\beta}_{ij}$
, where
 $$\begin{eqnarray}{\it\beta}_{ij}=-\frac{2}{n_{i}+n_{j}},\end{eqnarray}$$
which is exactly (8.12b ). Moreover, the whole pattern of the instability islands in figure 7(b) repeats the pattern of cells in the second and third bands shown in figure 2(a).
It is natural to ask what are the conditions for reconnection of the islands in the pairs that constitute each particular quadruplet. To get an idea we play with the two Rossby numbers in figure 8. We fix
 $\mathit{Ro}=-0.75$
and slightly increase
 $\mathit{Rb}$
. As a result, at
 $\mathit{Rb}=-0.74933$
the islands with the indices
 $n=-2$
and
 $n=0$
reconnect at
 ${\it\beta}_{-2,0}=1$
, figure 8(a). At
 $\mathit{Rb}=-0.747$
these islands overlap whereas the islands in the next quadruplet with
 $n=-3$
and
 $n=-1$
reconnect at
 ${\it\beta}_{-3,-1}=\frac{1}{2}$
, figure 8(b). At
 $\mathit{Rb}=-0.742$
the reconnection happens in the third quadruplet at
 ${\it\beta}_{-4,-2}=\frac{1}{3}$
, and so on, figure 8(c).
This sequence of reconnections indicates the special role of the line
 $\mathit{Ro}=\mathit{Rb}$
which seems to be even more pronounced in the inviscid limit
 $(\mathit{Re}\rightarrow \infty )$
. In the following we check these hypotheses when the magnetic field has only the azimuthal component which corresponds to the limit
 ${\it\beta}\rightarrow \infty$
.
9.2. AMRI as a dissipation-induced instability of Chandrasekhar’s equipartition solution
In the matrix (7.7) let us replace via the relation (8.27) the Elsasser number
 $\mathit{N}$
of the axial field with the Elsasser number of the azimuthal field
 $\mathit{N}_{A}$
and then let
 ${\it\beta}\rightarrow \infty$
. If, additionally
 $$\begin{eqnarray}\mathit{N}_{A}=\mathit{Rm}\end{eqnarray}$$
and
 $$\begin{eqnarray}\mathit{Ro}=Rb,\end{eqnarray}$$
then in the ideal limit (
 $\mathit{Re}\rightarrow \infty$
,
 $\mathit{Rm}\rightarrow \infty$
) the roots of the dispersion relation (7.6) are
 $$\begin{eqnarray}{\it\lambda}_{1,2}=0,\quad {\it\lambda}_{3,4}=-2\text{i}(n\pm 1).\end{eqnarray}$$
With the use of the relations (7.2) it is straightforward to verify that the condition (9.2) requires that
 ${\rm\Omega}={\it\omega}_{A_{{\it\phi}}}$
. Thus, the conditions (9.2) and (9.3) are equivalent to (6.15), which at
 $\mathit{Rb}=\mathit{Ro}=-1$
define the Chandrasekhar equipartition solution (Kirillov et al.
Reference Kirillov, Stefani and Fukumoto2014) belonging to a wide class of exact stationary solutions of MHD equations for the case of ideal incompressible infinitely conducting fluid with total constant pressure that includes even flows with knotted magnetic surfaces (Golovin & Krutikov Reference Golovin and Krutikov2012). It is well-known that the Chandrasekhar equipartition solution is marginally stable (Chandrasekhar Reference Chandrasekhar1956, Reference Chandrasekhar1961; Bogoyavlenskij Reference Bogoyavlenskij2004). According to (9.4) the marginal stability is also preserved in the ideal case when
 $\mathit{Rb}=\mathit{Ro}\neq -1$
. Will the roots (9.4) acquire only negative real parts with the addition of electrical resistivity?
(a) The threshold of instability (9.5) at
 $\mathit{N}_{A}=\mathit{ Rm}$
and
 $\mathit{Re}\rightarrow \infty$
in the
 $(n,\mathit{Rb},\mathit{Rm})$
space and (b) its projection onto the
 $\mathit{Rb}{-}n$
plane. The increase in
 $\mathit{Rm}$
makes the instability domain more narrow so that in the limit
 $\mathit{Rm}\rightarrow \infty$
it degenerates into a ray (dashed) on the straight line (9.6) that emerges from the point (open circle) with the coordinates
 $n=\frac{2\sqrt{3}}{3}$
and
 $\mathit{Rb}=-\frac{2}{3}$
and passes through the point with
 $n=1$
and
 $\mathit{Rb}=-1$
.

In general, the answer is no. Indeed, under the constraints (9.2) and (9.3) in the limit of vanishing viscosity (
 $\mathit{Re}\rightarrow \infty$
) the Bilharz criterion applied to the dispersion relation (7.6) gives the following threshold of instability:
 $$\begin{eqnarray}\displaystyle & & \displaystyle 16(n^{2}-\mathit{Rb}^{2})(n^{2}-\mathit{Rb}-2)^{2}\mathit{Rm}^{4}\nonumber\\ \displaystyle & & \displaystyle \quad +\,(n^{6}-12n^{2}\mathit{Rb}^{2}+32n^{2}(\mathit{Rb}+1)-16\mathit{Rb}^{2}(\mathit{Rb}+2))\mathit{Rm}^{2}\nonumber\\ \displaystyle & & \displaystyle \quad -\,4\mathit{Rb}^{2}+4n^{2}(\mathit{Rb}+1)=0.\end{eqnarray}$$
In the
 $(n,\mathit{Rb},\mathit{Rm})$
space the domain of instability is below the surface specified by (9.5), see figure 9(a). When the electrical resistivity is vanishing, the cross-sections of the instability domain in the
 $\mathit{Rb}{-}n$
plane become smaller and in the limit
 $\mathit{Rm}\rightarrow \infty$
they tend to the ray on the line
 $$\begin{eqnarray}\mathit{Rb}=-\frac{2}{3}+\frac{n\sqrt{3}-2}{3(2-\sqrt{3})}\end{eqnarray}$$
that starts at the point with the coordinates
 $n=\frac{2\sqrt{3}}{3}$
and
 $\mathit{Rb}=-\frac{2}{3}$
and passes through the point with
 $n=1$
and
 $\mathit{Rb}=-1$
, figure 9(b). For example, at
 $\mathit{ Ro}=Rb=-\frac{3}{4}$
(9.6) yields
 $$\begin{eqnarray}n=\frac{1}{4}+\frac{\sqrt{3}}{2}.\end{eqnarray}$$
On the other hand, when the magnetic Reynolds number
 $\mathit{Rm}$
decreases, the instability domain widens and in the inductionless limit at
 $\mathit{Rm}=0$
it is bounded by the curve
 $$\begin{eqnarray}\mathit{Rb}=\frac{n(n-\sqrt{n^{2}+4})}{2}.\end{eqnarray}$$
The wide part of the instability domain shown in figure 9(a) that exists at small
 $\mathit{Rm}$
belongs to the realm of the azimuthal magnetorotational instability (AMRI). We see that this instability quickly disappears with the increase of
 $\mathit{Rm}$
or
 $\mathit{Rb}$
. On the other hand, the ideal solution with the roots (9.4) that corresponds to the limit
 $\mathit{Rm}\rightarrow \infty$
is destabilized by the electrical resistivity. For
 $n$
given by (9.7) we have, for example, an unstable root
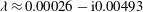 ${\it\lambda}\approx 0.00026-\text{i}0.00493$
at
 $\mathit{Rm}=100$
. In general, if
 $\mathit{Rb}$
and
 $n$
satisfy (9.6), then already an infinitesimally weak electrical resistivity has destabilized the solution specified by the constraints (9.2) and (9.3) at vanishing kinematic viscosity that includes Chandrasekhar’s equipartition solution as a special case. This dissipation-induced instability (Kirillov Reference Kirillov2009; Kirillov & Verhulst Reference Kirillov and Verhulst2010; Kirillov Reference Kirillov2013) further develops into the AMRI with
 $\mathit{Rm}$
decreasing to zero.
At
 $n\approx 1.27842$
(a) the domain of the inductionless AMRI bounded by the curve (10.2) with
 $\mathit{Ro}=-1$
and
 $\mathit{ Rb}=-1$
that gradually transforms into the domain that includes the Tayler instability (TI) as
 $\mathit{Rb}$
increases from
 $-1$
to 0; (b) Tayler instability corresponding to
 $\mathit{Ro}=0$
and
 $\mathit{Re}=0$
. The open circle marks the onset of the standard TI at
 $\mathit{Rb}=0$
with the critical
 $\mathit{Hb}\approx 1.04117$
.

10. Transition from AMRI to the Tayler instability
The Tayler instability (Tayler Reference Tayler1973; Rüdiger & Schultz Reference Rüdiger and Schultz2010) is a current-driven kink-type instability that taps into the magnetic field energy of the electrical current in the fluid. Although its plasma-physics counterpart has been known for a long time, its occurrence in a liquid metal was observed only recently (Seilmayer et al. Reference Seilmayer, Stefani, Gundrum, Weier, Gerbeth, Gellert and Rüdiger2012). In the context of the on-going liquid-metal experiments in the framework of the DRESDYN project (Stefani et al. Reference Stefani, Eckert, Gerbeth, Giesecke, Gundrum, Steglich, Weier and Wustmann2012) it is interesting to get insight into the transition between the azimuthal magnetorotational instability and the Tayler instability.
Consider the instability threshold (8.1) obtained in the inductionless approximation (
 $\mathit{Pm}=0$
). Let us introduce the Hartmann number corresponding to the pure azimuthal magnetic field as
 $$\begin{eqnarray}\mathit{Hb}:={\it\beta}\mathit{Ha},\end{eqnarray}$$
so that
 $\mathit{N}_{A}=\mathit{Hb}^{2}/\mathit{Re}$
. Substituting (10.1) into (8.1) and then letting
 ${\it\beta}\rightarrow \infty$
, we find
 $$\begin{eqnarray}\mathit{Re}^{2}=\frac{\left((1+\mathit{Hb}^{2}n^{2})^{2}-4\mathit{Hb}^{2}\mathit{Rb}(1+\mathit{ Hb}^{2}n^{2})-4\mathit{Hb}^{4}n^{2}\right)\left(1+\mathit{Hb}^{2}(n^{2}-2\mathit{Rb})\right)^{2}}{4\left(\mathit{ Hb}^{4}\mathit{Ro}^{2}n^{2}-((1+\mathit{Hb}^{2}(n^{2}-2\mathit{Rb}))^{2}-4\mathit{ Hb}^{4}n^{2})(\mathit{Ro}+1)\right)}.\end{eqnarray}$$
Note that the expression (10.2) can also be derived from (8.28).
Consider the threshold of instability (10.2) in the two special cases corresponding to the lower left and the upper right corners of the
 $\mathit{Ro}{-}\mathit{Rb}$
diagram shown in figure 3(b). At
 $\mathit{Ro}=-1$
and
 $\mathit{Rb}=-1$
the function
 $\mathit{Re}(n,\mathit{Hb})$
that bounds the domain of AMRI has a minimum
 $\mathit{Re}\approx 4.99083$
at
 $n\approx 1.27842$
and
 $\mathit{Hb}\approx 0.61185$
, see figure 10(a).
Putting
 $\mathit{Re}=0$
in (10.2), we find the threshold for the critical azimuthal magnetic field
 $$\begin{eqnarray}\mathit{Rb}=\frac{(\mathit{Hb}^{2}n^{2}+1)^{2}-4\mathit{Hb}^{4}n^{2}}{4\mathit{Hb}^{2}(1+\mathit{Hb}^{2}n^{2})}\end{eqnarray}$$
that destabilizes electrically conducting fluid at rest (cf. criterion (6.9)). At
 $\mathit{Rb}=0$
expression (10.3) gives the value of the azimuthal magnetic field at the onset of the standard Tayler instability (cf. criterion (6.10))
 $$\begin{eqnarray}\mathit{Hb}=\frac{1}{\sqrt{1-(1-|n|)^{2}}}.\end{eqnarray}$$
For example, at
 $n\approx 1.27842$
 $$\begin{eqnarray}\mathit{Hb}\approx 1.04117,\end{eqnarray}$$
see figure 10(b). In the following, we prefer to extend the notion of the Tayler instability (TI) to the whole domain bounded by the curve (10.3) and shown in grey in figure 10(b).
How are the domains of the Tayler instability and AMRI related to each other? Is there a connection between them in the parameter space?
As is seen in figure 10(b), with the decrease in
 $\mathit{Rb}$
, the critical value of
 $\mathit{Hb}$
at the onset of TI,
 $$\begin{eqnarray}\mathit{Hb}=\frac{1}{\sqrt{2\mathit{Rb }+2\sqrt{\mathit{Rb }^{2}+n^{2}}-n^{2}}},\end{eqnarray}$$
increases and, as follows from (10.3) and (10.6), tends to infinity as
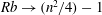 $\mathit{Rb}\rightarrow (n^{2}/4)-1$
. The asymptote
 $$\begin{eqnarray}\mathit{Rb}=\frac{n^{2}}{4}-1\end{eqnarray}$$
is shown in figure 10(b) as a horizontal dashed line. If we look at the instability domain in the
 $\mathit{Re}$
–
 $\mathit{Hb}$
plane at fixed
 $\mathit{Ro}$
and
 $n$
, then we will see how the domain of the pure AMRI gradually transforms into that containing the TI when
 $\mathit{Rb}$
varies from
 $-1$
to 0. The boundary of TI at
 $\mathit{Re}=0$
originates exactly at the point where
 $\mathit{Rb}=(n^{2}/4)-1$
, figure 10(a).
Let us look at the
 $\mathit{Ro}{-}\mathit{Rb}$
diagram shown in figure 3(b). To connect the two opposite corners of it we obviously need to take a path that lies below the line
 $\mathit{Ro}=Rb$
. Indeed, any path above this line penetrates the limiting curve (8.18) which creates an obstacle to connecting the two regions shown in figure 10. On the other hand, any path below the diagonal in figure 3(b) lies within the instability domain which opens a possibility of connecting the regions of AMRI and standard TI corresponding to
 $\mathit{Rb}=0$
and
 $\mathit{Ro}=0$
. Therefore, it is the dependence
 $\mathit{Ro}(\mathit{Rb})$
that controls the transition from the azimuthal magnetorotational instability to the Tayler instability.
Under the assumption that
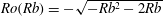 $\mathit{Ro}(\mathit{Rb})=-\sqrt{-\mathit{ Rb }^{2}-2\mathit{Rb}}$
and
 $n\approx 1.27842$
: (a) the domain of the inductionless instability bounded by the surface (10.2) in the
 $(\mathit{Hb},\mathit{Rb},\mathit{Re})$
space and its cross-sections at (b)
 $\mathit{Re}=5.4$
, (c)
 $\mathit{Re}=5.734$
, and (d)
 $\mathit{Re}=6$
. The domains of TI and AMRI reconnect via a saddle point at
 $\mathit{Re}=5.734$
.

The instability domain for the assumption that magnetic Prandtl number takes a finite value
 $\mathit{Pm}=0.05$
,
 $n=1.27842$
, and
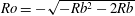 $\mathit{ Ro}=-\sqrt{-\mathit{Rb }^{2}-2\mathit{Rb}}$
at (a)
 $\mathit{Re}=0$
, (b)
 $\mathit{Re}=3.8$
, (c)
 $\mathit{Re}=3.958$
, (d)
 $\mathit{Re}=4.2$
.

At
 $\mathit{Pm}=0.05$
,
 $n=1.27842$
,
 $\mathit{Re}=3.8$
, and
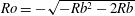 $\mathit{ Ro}=-\sqrt{-Rb^{2}-2Rb}$
: (a) the growth rates
 ${\it\lambda}_{r}(\mathit{Hb})$
as
 $\mathit{Rb}$
changes from
 $-1$
to
 $0$
; (b) the movement of the roots in the complex plane for (fine lines)
 $\mathit{Rb}=-1$
and (bold lines)
 $\mathit{Rb}=0$
.

Assume, for example, that
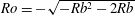 $\mathit{Ro}=-\sqrt{-Rb^{2}-2Rb}$
, which is part of the unit circle that connects the point with
 $\mathit{Rb}=-1$
and
 $\mathit{Ro}=-1$
and the point with
 $\mathit{Rb}=0$
and
 $\mathit{Ro}=0$
in figure 3(b). Substituting this dependence into the expression (10.2), we can plot the domain of instability in the
 $(\mathit{Hb},\mathit{ Rb},\mathit{Re})$
space for a given
 $n$
, figure 11(a). The cross-section of the domain at
 $\mathit{Re}=0$
yields exactly the region of the Tayler instability shown in figure 10(b). The cross-section at
 $\mathit{Rb}=-1$
is the domain of AMRI in figure 10(a).
At
 $\mathit{Re}<4.99083...$
the azimuthal MRI with
 $n\approx 1.27842$
at
 $\mathit{Rb}=-1$
does not exist. With the increase in the Reynolds number the island of AMRI is originated, figure 11(b), that further reconnects with the viscosity-modified domain of TI at a saddle point, figure 11(c). At higher values of
 $\mathit{Re}$
the two domains merge into one, figure 11(d).
What happens with the inductionless instability diagram of figure 11 when the magnetic Prandtl number takes finite values? It turns out that at
 $\mathit{Pm}\ll 1$
the difference is very small and is not qualitative. Moreover, at
 $\mathit{Re}=0$
the domain of the Tayler instability is still given by (10.3) and thus coincides with that shown in figure 10(b). Nevertheless, the critical Reynolds number at the saddle point and at the onset of AMRI slightly decreases with the increase in
 $\mathit{Pm}$
, figure 12.
Finally, we plot in figure 13(a) the growth rates
 ${\it\lambda}_{r}(\mathit{Hb})$
as
 $\mathit{Rb}$
varies from
 $-1$
to 0. One can see that the growth rates of the Tayler instability monotonically increase and become positive at
 $\mathit{Hb}>1$
. When
 $\mathit{Rb}$
is smaller than about
 $-0.5$
, the function
 ${\it\lambda}_{r}(\mathit{Hb})$
has a maximum that can both lie below zero and exceed it in dependence on
 $\mathit{Rb}$
. The latter weak instability is the azimuthal magnetorotational instability.
In figure 13(b) the movement of the roots corresponding to TI and AMRI is presented. There are indications that the origin of both instabilities might be related to the splitting of a multiple zero root. Note that in the inductionless case a detailed analysis of the movement of the roots and their bifurcation is possible with the use of (8.24) and (8.28). We leave this for a future work.
11. Conclusion
Using the formal short-wavelength asymptotic expansions of geometric optics, we have derived the local transport partial differential equations (PDEs) for the amplitude of the localized non-axisymmetric perturbation of a rotating flow under the influence of a constant vertical magnetic field and an azimuthal magnetic field with arbitrary radial dependence. Looking for the solution of the local transport PDEs in modal form we have derived a dispersion relation of AMRI that is suitable for testing stability in the case of both ideal and dissipative MHD. The dispersion relation of HMRI in a viscous and resistive setup is derived separately by applying the WKB approximation in the radial direction only. Particularly, in the limit of vanishing magnetic Prandtl number as well as for small, but finite,
 $\mathit{Pm}$
, we have shown that Keplerian profiles can be destabilized by HMRI or AMRI if only the azimuthal field profile is slightly flatter than
 $1/R$
. We have also shown that the line where the hydrodynamic and the magnetic Rossby numbers are equal plays an essential role for the connectedness of the instability domain. We have found that the marginally stable solution corresponding to
 $\mathit{ Ro}=Rb$
and
 $\mathit{N}_{A}=\mathit{Rm}$
in the limit when both
 $\mathit{Re}\rightarrow \infty$
and
 $\mathit{Rm}\rightarrow \infty$
is generically destabilized by weak but finite electrical resistivity (and in particular cases already by infinitesimally weak electrical resistivity) resulting in AMRI, which is therefore a dissipation-induced instability. In particular, when
 $\mathit{N}_{A}=\mathit{ Rm}$
and
 $\mathit{Ro}=Rb=-1$
, AMRI is a dissipation-induced instability of the Chandrasekhar equipartition solution of ideal MHD. Finally, we have found an analytical condition on
 $\mathit{Rb}$
separating the regimes of pure AMRI and Tayler instability.
With a view to astrophysical applications one has definitely to note that any profile of
 $B_{{\it\phi}}$
flatter than
 $1/R$
would require some finite magnetic Reynolds number for the necessary induction effects to occur. Nevertheless, our results still provide a real extension of the applicability of MRI, since the Lundquist numbers are allowed to be arbitrarily small, although the growth rate, which is proportional to the interaction parameter, would then be rather small.
The consequences of our findings for those parts of accretion disks with small magnetic Prandtl numbers are still to be elaborated. The action of MRI in the dead zones of protoplanetary disks is an example for which the extended parameter region might have consequences. Particular attention should also be given to the possibility of quasi-periodic oscillations which might easily result from the sensitive dependence of the action of HMRI on the radial profile of
 $B_{{\it\phi}}$
and the ratio of the latter to
 $B_{z}$
. We notice however that pure hydrodynamical scenarios of transition to turbulence in the dead zones have also been proposed (Marcus et al.
Reference Marcus, Pei, Jiang and Hassanzadeh2013).
Regarding liquid-metal experiments, our results give strong impetus for a special setup in which the magnetic Rossby number can be adjusted by using two independent electrical currents: one through an central, insulated rod, the second one through the liquid metal. A liquid-sodium experiment dedicated exactly to this problem is at present being designed in the framework of the DRESDYN project (Stefani et al. Reference Stefani, Eckert, Gerbeth, Giesecke, Gundrum, Steglich, Weier and Wustmann2012). Apart from this, the recently observed, and numerically confirmed, strong sensitivity of AMRI to a slight symmetry breaking of an external magnetic field (Seilmayer et al. Reference Seilmayer, Galindo, Gerbeth, Gundrum, Stefani, Gellert, Rüdiger, Schultz and Hollerbach2014) may also be related to our findings.
Acknowledgements
This work was supported by Helmholtz-Gemeinschaft Deutscher Forschungszentren (HGF) in frame of the Helmholtz Alliance LIMTECH, as well as by Deutsche Forschungsgemeinschaft in frame of the SPP 1488 (PlanetMag). F.S. acknowledges fruitful discussions with M. Gellert, R. Hollerbach, and G. Rüdiger. We thank an anonymous referee for helpful comments.
Appendix A. Connection to the work by Friedlander & Vishik (Reference Friedlander and Vishik1995)
Friedlander & Vishik (Reference Friedlander and Vishik1995) considered stability with respect to non-axisymmetric perturbation of the general toroidal ideal MHD equilibrium with
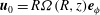 $\boldsymbol{u}_{0}=R{\rm\Omega}(R,z)\boldsymbol{e}_{{\it\phi}}$
and
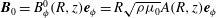 $\boldsymbol{B}_{0}=B_{{\it\phi}}^{0}(R,z)\boldsymbol{e}_{{\it\phi}}=R\sqrt{{\it\rho}{\it\mu}_{0}}A(R,z)\boldsymbol{e}_{{\it\phi}}$
, where the equilibrium equation requires
 $\partial _{z}({\rm\Omega}^{2}-A^{2})=0$
. If we neglect the
 $z$
-dependence and assume that the artificially introduced quantization constant
 ${\it\tau}=0$
, their dispersion relation derived in the short-wavelength approximation is given by the characteristic polynomial of the matrix
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D641}=\!\left(\begin{array}{@{}cccc@{}}-\text{i}m({\rm\Omega}-A) & {\it\alpha}^{2}({\rm\Omega}-A) & 0 & {\it\alpha}^{2}({\rm\Omega}+A)\\ A-{\rm\Omega} & -\text{i}m({\rm\Omega}-A) & -A-{\rm\Omega}-R\partial _{R}({\rm\Omega}+A) & 0\\ 0 & {\it\alpha}^{2}({\rm\Omega}-A) & -\text{i}m({\rm\Omega}+A) & {\it\alpha}^{2}({\rm\Omega}+A)\\ A-{\rm\Omega}-R\partial _{R}({\rm\Omega}-A) & 0 & -({\rm\Omega}+A) & -\text{i}m({\rm\Omega}+A)\\ \end{array}\right), & & \displaystyle \nonumber\\ \displaystyle & & \displaystyle\end{eqnarray}$$
where
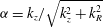 ${\it\alpha}=k_{z}/\sqrt{k_{z}^{2}+k_{R}^{2}}$
,
 $A={\it\omega}_{A_{{\it\phi}}}$
, and according to (2.5) and (4.6),
 $R\partial _{R}{\rm\Omega}=2{\rm\Omega}\mathit{Ro}$
and
 $R\partial _{R}A=2{\it\omega}_{A_{{\it\phi}}}\mathit{Rb}$
. In the new notation the coefficients of the dispersion relation derived by Friedlander & Vishik (Reference Friedlander and Vishik1995) exactly coincide with those given by (B 1) where one has to set
 ${\it\omega}_{{\it\nu}}=0$
,
 ${\it\omega}_{{\it\eta}}=0$
, and
 ${\it\omega}_{A_{z}}=0$
.
To show this, we add/subtract the amplitude equation (3.15b
) divided by
 $\sqrt{{\it\rho}{\it\mu}_{0}}$
to/from (3.15a
) in order to write it via the Elsasser variables
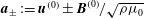 $\boldsymbol{a}_{\pm }:=\boldsymbol{u}^{(0)}\pm \boldsymbol{B}^{(0)}/\sqrt{{\it\rho}{\it\mu}_{0}}$
:
 $$\begin{eqnarray}\displaystyle \dot{\boldsymbol{a}}_{+} & = & \displaystyle -\left(\left[\boldsymbol{u}_{0}-\frac{\boldsymbol{B}_{0}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\right]\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\right)\boldsymbol{a}_{+}-\left({\mathcal{U}}+\frac{{\mathcal{B}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\right)\boldsymbol{a}_{-}-\frac{{\it\omega}_{{\it\nu}}+{\it\omega}_{{\it\eta}}}{2}\boldsymbol{a}_{+}-\frac{{\it\omega}_{{\it\nu}}-{\it\omega}_{{\it\eta}}}{2}\boldsymbol{a}_{-}\nonumber\\ \displaystyle & & \displaystyle \quad +\,\frac{\boldsymbol{k}\boldsymbol{k}^{\text{T}}}{|\boldsymbol{k}|^{2}}\left(\left[{\mathcal{U}}+\frac{{\mathcal{B}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\right]\boldsymbol{a}_{-}+\left[{\mathcal{U}}-\frac{{\mathcal{B}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\right]\boldsymbol{a}_{+}\right)\nonumber\\ \displaystyle & & \displaystyle \quad +\,\frac{\boldsymbol{k}\boldsymbol{k}^{\text{T}}}{|\boldsymbol{k}|^{2}}\left(\frac{{\mathcal{B}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}-\left(\frac{\boldsymbol{B}_{0}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\right)\right)\frac{\boldsymbol{a}_{+}-\boldsymbol{a}_{-}}{2},\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \dot{\boldsymbol{a}}_{-} & = & \displaystyle -\left(\left[\boldsymbol{u}_{0}+\frac{\boldsymbol{B}_{0}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\right]\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\right)\boldsymbol{a}_{-}-\left({\mathcal{U}}-\frac{{\mathcal{B}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\right)\boldsymbol{a}_{+}-\frac{{\it\omega}_{{\it\nu}}+{\it\omega}_{{\it\eta}}}{2}\boldsymbol{a}_{-}-\frac{{\it\omega}_{{\it\nu}}-{\it\omega}_{{\it\eta}}}{2}\boldsymbol{a}_{+}\nonumber\\ \displaystyle & & \displaystyle \quad +\,\frac{\boldsymbol{k}\boldsymbol{k}^{\text{T}}}{|\boldsymbol{k}|^{2}}\left(\left[{\mathcal{U}}+\frac{{\mathcal{B}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\right]\boldsymbol{a}_{-}+\left[{\mathcal{U}}-\frac{{\mathcal{B}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\right]\boldsymbol{a}_{+}\right)\nonumber\\ \displaystyle & & \displaystyle \quad +\,\frac{\boldsymbol{k}\boldsymbol{k}^{\text{T}}}{|\boldsymbol{k}|^{2}}\left(\frac{{\mathcal{B}}}{\sqrt{{\it\rho}{\it\mu}_{0}}}-\left(\frac{\boldsymbol{B}_{0}}{\sqrt{{\it\rho}{\it\mu}_{0}}}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\right)\right)\frac{\boldsymbol{a}_{+}-\boldsymbol{a}_{-}}{2}.\end{eqnarray}$$
 $\boldsymbol{a}_{\pm }=\widehat{\boldsymbol{a}}_{\pm }\text{e}^{{\it\gamma}t+\text{i}m{\it\phi}}$
, taking into account that
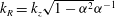 $k_{R}=k_{z}\sqrt{1-{\it\alpha}^{2}}{\it\alpha}^{-1}$
, and eliminating the
 $z$
-components of the vectors
 $\boldsymbol{a}_{\pm }$
via the constraints
 $\boldsymbol{a}_{\pm }\boldsymbol{\cdot }\boldsymbol{k}=0$
following from (3.6) we arrive at the equation
 $\unicode[STIX]{x1D641}\widehat{\boldsymbol{b}}={\it\gamma}\widehat{\boldsymbol{b}}$
, where
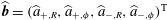 $\widehat{\boldsymbol{b}}=(\widehat{a}_{+,R},\widehat{a}_{+,{\it\phi}},\widehat{a}_{-,R},\widehat{a}_{-,{\it\phi}})^{\text{T}}$
and
 $\unicode[STIX]{x1D641}$
is the matrix defined above in the case when
 ${\it\omega}_{{\it\nu}}=0$
and
 ${\it\omega}_{{\it\eta}}=0$
.
Appendix B. Coefficients of the dispersion relations
The complex characteristic polynomial equation (5.10) of the matrix (5.8) has the following coefficients:
 $$\begin{eqnarray}\displaystyle a_{0}=1,\quad b_{0}=0,\quad a_{1}=2({\it\omega}_{{\it\eta}}+{\it\omega}_{{\it\nu}}),\quad b_{1}=4m{\rm\Omega}, & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{2} & = & \displaystyle -4{\it\alpha}^{2}{\it\omega}_{A_{{\it\phi}}}^{2}\mathit{Rb}+4{\it\alpha}^{2}{\rm\Omega}^{2}(1+\mathit{Ro})+({\it\omega}_{{\it\nu}}+{\it\omega}_{{\it\eta}})^{2}\nonumber\\ \displaystyle & & \displaystyle -\,2(3m^{2}{\rm\Omega}^{2}-(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})^{2}-{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle b_{2}={\textstyle \frac{3}{4}}a_{1}b_{1}, & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{3} & = & \displaystyle 2({\it\omega}_{{\it\nu}}+{\it\omega}_{{\it\eta}})(-2{\it\alpha}^{2}{\it\omega}_{A_{{\it\phi}}}^{2}\mathit{Rb}-(3m^{2}{\rm\Omega}^{2}-(m{\it\omega}_{A_{{\it\phi}}}+{\it\omega}_{A_{z}})^{2}-{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}))\nonumber\\ \displaystyle & & \displaystyle +\,8{\it\alpha}^{2}{\rm\Omega}^{2}{\it\omega}_{{\it\eta}}(1+\mathit{Ro}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle b_{3}=\frac{a_{2}b_{1}}{2}+\frac{b_{1}^{3}}{8}-8{\rm\Omega}{\it\alpha}^{2}({\it\omega}_{A_{z}}+m{\it\omega}_{A_{{\it\phi}}}){\it\omega}_{A_{{\it\phi}}}, & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{4} & = & \displaystyle ((4{\rm\Omega}^{2}({\it\omega}_{A_{z}}+m{\it\omega}_{A_{{\it\phi}}})^{2}-4{\rm\Omega}^{4}m^{2}+4{\rm\Omega}^{2}{\it\omega}_{{\it\eta}}^{2})\mathit{Ro}+8{\it\omega}_{A_{{\it\phi}}}{\it\omega}_{A_{z}}m{\rm\Omega}^{2}\nonumber\\ \displaystyle & & \displaystyle +\,4{\rm\Omega}^{2}{\it\omega}_{{\it\eta}}^{2}-4{\rm\Omega}^{4}m^{2} ){\it\alpha}^{2}-{\rm\Omega}^{2}m^{2}({\it\omega}_{{\it\nu}}+{\it\omega}_{{\it\eta}})^{2}+(m^{2}{\rm\Omega}^{2}-({\it\omega}_{A_{z}}+m{\it\omega}_{A_{{\it\phi}}})^{2}-{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}})^{2}\nonumber\\ \displaystyle & & \displaystyle +\,4(\mathit{Rb}+1){\it\omega}_{A_{{\it\phi}}}^{2}{\it\alpha}^{2}(m^{2}{\rm\Omega}^{2}-({\it\omega}_{A_{z}}+m{\it\omega}_{A_{{\it\phi}}})^{2})+4{\it\omega}_{A_{{\it\phi}}}^{2}{\it\alpha}^{2}(m^{2}{\rm\Omega}^{2}-{\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}\mathit{Rb}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle b_{4} & = & \displaystyle -4m{\rm\Omega}{\it\alpha}^{2}[(\mathit{Ro}+1)({\it\omega}_{{\it\eta}}-{\it\omega}_{{\it\nu}})+(\mathit{Rb}+1)({\it\omega}_{{\it\eta}}+{\it\omega}_{{\it\nu}})]{\it\omega}_{A_{{\it\phi}}}^{2}\nonumber\\ \displaystyle & & \displaystyle -\,4{\it\omega}_{A_{z}}{\rm\Omega}{\it\alpha}^{2}(\mathit{Ro}({\it\omega}_{{\it\eta}}-{\it\omega}_{{\it\nu}})+2{\it\omega}_{{\it\eta}}){\it\omega}_{A_{{\it\phi}}}\nonumber\\ \displaystyle & & \displaystyle +\,2m{\rm\Omega}(4{\it\alpha}^{2}{\rm\Omega}^{2}{\it\omega}_{{\it\eta}}(\mathit{Ro}+1)+({\it\omega}_{{\it\nu}}+{\it\omega}_{{\it\eta}})({\it\omega}_{{\it\nu}}{\it\omega}_{{\it\eta}}-m^{2}{\rm\Omega}^{2}+({\it\omega}_{A_{z}}+m{\it\omega}_{A_{{\it\phi}}})^{2})).\end{eqnarray}$$
The coefficients of the complex polynomial equation (7.3) are
 $$\begin{eqnarray}\displaystyle a_{0}=1,\quad b_{0}=0,\quad a_{1}=2\left(\sqrt{\mathit{Pm}}+\frac{1}{\sqrt{\mathit{Pm}}}\right),\quad b_{1}=4n\mathit{Re}\sqrt{\mathit{Pm}}, & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{2} & = & \displaystyle 2({\it\beta}^{2}\mathit{Ha}^{2}-3\mathit{Re}^{2}\mathit{Pm})n^{2}+4{\it\beta}\mathit{Ha}^{2}n\nonumber\\ \displaystyle & & \displaystyle +\,2(1+(1-2\mathit{Rb}{\it\beta}^{2})\mathit{Ha}^{2})+4\mathit{Re}^{2}(1+\mathit{Ro})\mathit{Pm}+\frac{a_{1}^{2}}{4},\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle b_{2}=6n\mathit{Re}(1+\mathit{Pm}), & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{3} & = & \displaystyle a_{1}({\it\beta}^{2}\mathit{Ha}^{2}-3\mathit{Re}^{2}\mathit{Pm})n^{2}+2a_{1}{\it\beta}\mathit{Ha}^{2}n\nonumber\\ \displaystyle & & \displaystyle +\,a_{1}(1+(1-2\mathit{Rb}{\it\beta}^{2})\mathit{Ha}^{2})+8\mathit{Re}^{2}(1+\mathit{Ro})\sqrt{\mathit{Pm}},\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle b_{3} & = & \displaystyle 4n^{3}\sqrt{\mathit{Pm}}\mathit{Re}({\it\beta}^{2}\mathit{Ha}^{2}-\mathit{Re}^{2}\mathit{Pm})\nonumber\\ \displaystyle & & \displaystyle +\,2n\mathit{Re}(4\mathit{Pm}^{2}\mathit{Re}^{2}(1+\mathit{Ro})+(1+\mathit{Pm})^{2}+2\mathit{Pm}(1+\mathit{Ha}^{2}))/\sqrt{\mathit{Pm}}\nonumber\\ \displaystyle & & \displaystyle -\,8(1-n^{2}+{\it\beta}n(1+\mathit{Rb})){\it\beta}\mathit{Ha}^{2}\mathit{Re}\sqrt{\mathit{Pm}},\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{4} & = & \displaystyle (({\it\beta}^{2}\mathit{Ha}^{2}-\mathit{Re}^{2}\mathit{Pm})n^{2}+2\mathit{Ha}^{2}{\it\beta}n+\mathit{Ha}^{2}+2\mathit{Pm}\mathit{Re}^{2})^{2}\nonumber\\ \displaystyle & & \displaystyle +\,2(2\mathit{Re}^{2}\mathit{Pm}\mathit{Ro}+1)((\mathit{Ha}^{2}{\it\beta}^{2}-\mathit{Re}^{2}\mathit{Pm})n^{2}+2\mathit{Ha}^{2}{\it\beta}n+\mathit{Ha}^{2})-(1+\mathit{Pm})^{2}\mathit{Re}^{2}n^{2}\nonumber\\ \displaystyle & & \displaystyle +\,4\mathit{Re}^{2}(1+\mathit{Ro})-(\mathit{Ha}^{2}+2\mathit{Pm}\mathit{Re}^{2})^{2}+\mathit{Ha}^{4}+1-4\mathit{Rb}{\it\beta}^{2}\mathit{Ha}^{2}\nonumber\\ \displaystyle & & \displaystyle -\,4\mathit{Ha}^{2}{\it\beta}^{2}(\mathit{Ha}^{2}({\it\beta}n+1)^{2}-\mathit{Pm}\mathit{Re}^{2}n^{2})(1+\mathit{Rb}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle b_{4} & = & \displaystyle 2\mathit{Re}(1+\mathit{Pm})({\it\beta}^{2}\mathit{Ha}^{2}-\mathit{Re}^{2}\mathit{Pm})n^{3}+4\mathit{Re}\mathit{Ha}^{2}{\it\beta}(1+\mathit{Pm})n^{2}\nonumber\\ \displaystyle & & \displaystyle +\,2\mathit{Re}(2(1+\mathit{Ro})(2\mathit{Re}^{2}\mathit{Pm}-{\it\beta}^{2}\mathit{Ha}^{2}(1-\mathit{Pm}))\nonumber\\ \displaystyle & & \displaystyle +\,(1+\mathit{Pm})(1+\mathit{Ha}^{2}(1-2{\it\beta}^{2}(1+\mathit{Rb}))))n-4{\it\beta}\mathit{Ha}^{2}\mathit{Re}(2+(1-\mathit{Pm})\mathit{Ro}).\end{eqnarray}$$
The next set of equations give the coefficients of the dispersion relation (7.6):
 $$\begin{eqnarray}\displaystyle a_{0}=1,\quad b_{0}=0,\quad a_{1}=2\left(\frac{1}{\mathit{Re}}+\frac{1}{\mathit{Rm}}\right),\quad b_{1}=4n, & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{2} & = & \displaystyle 2\left(\frac{{\it\beta}^{2}\mathit{N}}{\mathit{Rm}}-3\right)n^{2}+\frac{4{\it\beta}\mathit{N}}{\mathit{Rm}}n\nonumber\\ \displaystyle & & \displaystyle +\,\frac{2}{\mathit{Rm}}\left(\frac{1}{\mathit{Re }}+(1-2\mathit{Rb}{\it\beta}^{2})\mathit{N}\right)+4(1+\mathit{Ro})+\frac{a_{1}^{2}}{4},\quad b_{2}=\frac{3}{4}a_{1}b_{1},\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{3} & = & \displaystyle a_{1}\left(\frac{{\it\beta}^{2}\mathit{N}}{\mathit{Rm}}-3\right)n^{2}+2a_{1}{\it\beta}\frac{\mathit{N}}{\mathit{Rm}}n+\frac{a_{1}}{\mathit{Rm}}\left(\frac{1}{\mathit{Re}}+(1-2\mathit{Rb}{\it\beta}^{2})\mathit{N}\right)\nonumber\\ \displaystyle & & \displaystyle +\,\frac{8}{\mathit{Rm}}(1+\mathit{Ro}),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle b_{3} & = & \displaystyle 4\left(\frac{{\it\beta}^{2}\mathit{N}}{\mathit{Rm}}-1\right)n^{3}+2n\left(4(1+\mathit{Ro})+\frac{a_{1}^{2}}{4}+\frac{2}{\mathit{Rm}}\left(\frac{1}{\mathit{Re}}+\mathit{N}\right)\right)\nonumber\\ \displaystyle & & \displaystyle -\,8(1-n^{2}+{\it\beta}n(1+\mathit{Rb}))\frac{{\it\beta}\mathit{N}}{\mathit{Rm}},\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle a_{4} & = & \displaystyle \left(\frac{{\it\beta}^{2}\mathit{N}}{\mathit{Rm}}-1\right)^{2}n^{4}+\frac{4{\it\beta}\mathit{N}}{\mathit{Rm}}\left(\frac{{\it\beta}^{2}\mathit{N}}{\mathit{Rm}}-1\right)n^{3}\nonumber\\ \displaystyle & & \displaystyle +\,\left(\frac{2}{\mathit{Rm}}\left(\frac{{\it\beta}^{2}\mathit{N}}{\mathit{Rm}}-1\right)\left(\mathit{N}+\frac{1}{\mathit{Re}}-2({\it\beta}^{2}(1+\mathit{Rb})\mathit{N}-(1+\mathit{Ro})\mathit{Rm})\right)+\frac{4\mathit{N}^{2}{\it\beta}^{2}}{\mathit{Rm}^{2}}-\frac{a_{1}^{2}}{4}\right)n^{2}\nonumber\\ \displaystyle & & \displaystyle +\,\frac{4\mathit{N}{\it\beta}}{\mathit{Rm}^{2}}\left(\mathit{N}+\frac{1}{\mathit{Re}}-2({\it\beta}^{2}(1+\mathit{Rb})\mathit{N}-(1+\mathit{Ro})\mathit{Rm})\right)n\nonumber\\ \displaystyle & & \displaystyle +\,\frac{1}{\mathit{Rm}^{2}}\left(\left(\mathit{N}+\frac{1}{\mathit{Re}}\right)^{2}-4\mathit{N}\left(\frac{{\it\beta}^{2}\mathit{Rb}}{\mathit{Re}}-\mathit{ Ro Rm}\right)+4(1+\mathit{Ro})-4\mathit{N}^{2}{\it\beta}^{2}(1+\mathit{Rb})\right),\nonumber\\ \displaystyle & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle b_{4} & = & \displaystyle a_{1}\left(\frac{{\it\beta}^{2}\mathit{N}}{\mathit{Rm}}-1\right)n^{3}+2a_{1}\frac{{\it\beta}\mathit{N}}{\mathit{Rm}}n^{2}-\frac{4{\it\beta}\mathit{N}}{\mathit{Rm}}\left(\frac{2}{\mathit{Rm}}+\left(\frac{1}{\mathit{Rm}}-\frac{1}{\mathit{Re}}\right)\mathit{Ro}\right)\nonumber\\ \displaystyle & & \displaystyle +\,\left(\frac{a_{1}}{\mathit{Rm}}\left(\frac{1}{\mathit{Re}}+(1+2{\it\beta}^{2}(\mathit{Ro}-\mathit{Rb}))\mathit{N}\right)-\frac{8(1+\mathit{Ro})}{\mathit{Rm}}\left(\frac{{\it\beta}^{2}\mathit{N}}{\mathit{Rm}}-1\right)\right)n.\end{eqnarray}$$
Appendix C. Connection to the work by Krueger et al. (Reference Krueger, Gross and Di Prima1966)
The background flow in the Taylor–Couette cell between two co-axial cylinders of infinite length that rotate about their common axis is
 $$\begin{eqnarray}{\rm\Omega}(R)=a+\frac{b}{R^{2}},\end{eqnarray}$$
where
 $$\begin{eqnarray}a=\frac{{\it\mu}_{{\rm\Omega}}-\hat{{\it\eta}}^{2}}{1-\hat{{\it\eta}}^{2}}{\rm\Omega}_{1},\quad b=\frac{1-{\it\mu}_{{\rm\Omega}}}{1-\hat{{\it\eta}}^{2}}R_{1}^{2}{\rm\Omega}_{1},\quad \hat{{\it\eta}}=\frac{R_{1}}{R_{2}},\quad {\it\mu}_{{\rm\Omega}}=\frac{{\rm\Omega}_{2}}{{\rm\Omega}_{1}},\end{eqnarray}$$
and
 $R_{1}$
and
 $R_{2}$
and
 ${\rm\Omega}_{1}$
and
 ${\rm\Omega}_{2}$
are the radii and angular velocities of the inner and outer cylinder, respectively. The centrifugal acceleration of the background flow (C 1) is compensated by the pressure gradient:
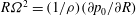 $R{\rm\Omega}^{2}=(1/{\it\rho})(\partial p_{0}/\partial R)$
. In view of the definition (2.5)
 $$\begin{eqnarray}a={\rm\Omega}(1+\mathit{Ro}).\end{eqnarray}$$
In the case when the gap between the cylinders
 $d=R_{2}-R_{1}$
is small with respect to the radii, the linearized equations derived by Krueger et al. (Reference Krueger, Gross and Di Prima1966) for the stability of the viscous Taylor–Couette flow of hydrodynamics with respect to non-axisymmetric disturbances have the form
 $$\begin{eqnarray}L(\text{D}^{2}-(k_{z}d)^{2})u^{\prime }=-(k_{z}d)^{2}T{\rm\Omega}_{l}(x)v^{\prime },\quad Lv^{\prime }=u^{\prime },\end{eqnarray}$$
where
 $\text{D}=\text{d}/\text{d}x$
,
 $R=R_{1}+xd$
,
 $\text{d}/\text{d}R=d^{-1}\text{d}/\text{d}x$
,
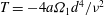 $T=-4a{\rm\Omega}_{1}d^{4}/{\it\nu}^{2}$
,
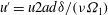 $u^{\prime }=u2ad{\it\delta}/({\it\nu}{\rm\Omega}_{1})$
,
 $v^{\prime }=v/(R_{1}{\rm\Omega}_{1})$
,
 ${\it\delta}=d/R_{1}$
,
 $$\begin{eqnarray}L=\text{D}^{2}-(k_{z}d)^{2}-\text{i}({\it\sigma}+k\sqrt{T}\ {\rm\Omega}_{l}(x)),\quad {\rm\Omega}_{l}(x)=1-(1-{\it\mu}_{{\rm\Omega}})x,\ x\in [0,1],\end{eqnarray}$$
 ${\it\sigma}={\it\omega}d^{2}/{\it\nu}$
, and
 $k=m\sqrt{-{\rm\Omega}_{1}/4a}$
.
For any
 $w\sim \exp (\text{i}k_{R}R)$
, we have
 $$\begin{eqnarray}\displaystyle Lw & = & \displaystyle -\frac{d^{2}}{{\it\nu}}\left({\it\nu}(k_{R}^{2}+k_{z}^{2})+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)w\nonumber\\ \displaystyle & = & \displaystyle -\frac{d^{2}}{{\it\nu}}\left({\it\nu}|\boldsymbol{k}|^{2}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)w=-\frac{d^{2}}{{\it\nu}}\left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)w.\end{eqnarray}$$
Consequently, if
 $u,v\sim \exp (\text{i}k_{R}R)$
, (C 4a
) becomes
 $$\begin{eqnarray}\displaystyle -\frac{d^{2}}{{\it\nu}}\left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)(-d^{2}|\boldsymbol{k}|^{2})\frac{2ad{\it\delta}}{{\it\nu}{\rm\Omega}_{1}}u=-k_{z}^{2}d^{2}(-4a{\rm\Omega}_{1}d^{4})\frac{{\rm\Omega}_{l}}{{\it\nu}^{2}R_{1}{\rm\Omega}_{1}}v. & & \displaystyle\end{eqnarray}$$
Simplifying this equation yields
 $$\begin{eqnarray}\left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)|\boldsymbol{k}|^{2}u=vk_{z}^{2}2{\rm\Omega}_{1}{\rm\Omega}_{l}\frac{d}{{\it\delta}R_{1}},\end{eqnarray}$$
and, finally,
 $$\begin{eqnarray}\left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)u=2{\it\alpha}^{2}{\rm\Omega}_{1}{\rm\Omega}_{l}v,\end{eqnarray}$$
where
 ${\it\alpha}=k_{z}/|\boldsymbol{k}|$
. Analogously, (C 4b
) takes the form
 $$\begin{eqnarray}\left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)v=-2au\frac{{\it\delta}R_{1}}{d},\end{eqnarray}$$
and, finally,
 $$\begin{eqnarray}\left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)v=-2{\rm\Omega}(1+\mathit{Ro})u.\end{eqnarray}$$
The equations (C 9) and (C 11) constitute the following system:
 $$\begin{eqnarray}\displaystyle \left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)u & = & \displaystyle 2{\it\alpha}^{2}{\rm\Omega}_{1}{\rm\Omega}_{l}v,\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega}_{1}{\rm\Omega}_{l})\right)v & = & \displaystyle -2{\rm\Omega}(1+\mathit{Ro})u.\end{eqnarray}$$
 ${\rm\Omega}\approx {\rm\Omega}_{1}{\rm\Omega}_{l}$
, then
 $$\begin{eqnarray}\displaystyle \left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega})\right)u & = & \displaystyle 2{\it\alpha}^{2}{\rm\Omega}v,\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \left({\it\omega}_{{\it\nu}}+\text{i}({\it\omega}+m{\rm\Omega})\right)v & = & \displaystyle -2{\rm\Omega}(1+\mathit{Ro})u.\end{eqnarray}$$
 $\unicode[STIX]{x1D63C}\boldsymbol{w}=\text{i}{\it\omega}\boldsymbol{w}$
with the vector
 $\boldsymbol{w}=(u,v)^{\text{T}}$
and
 $$\begin{eqnarray}\unicode[STIX]{x1D63C}=\left(\begin{array}{@{}cc@{}}-\text{i}m{\rm\Omega}-{\it\omega}_{{\it\nu}} & 2{\it\alpha}^{2}{\rm\Omega}\\ -2{\rm\Omega}(1+\mathit{Ro}) & -\text{i}m{\rm\Omega}-{\it\omega}_{{\it\nu}}\\ \end{array}\right).\end{eqnarray}$$
The matrix
 $\unicode[STIX]{x1D63C}$
is nothing else but the submatrix of the matrix
 $\unicode[STIX]{x1D643}$
defined by (5.8) situated at the corner corresponding to the first two rows and first two columns of
 $\unicode[STIX]{x1D643}$
.
Let
 $\unicode[STIX]{x1D63C}_{0}=\unicode[STIX]{x1D63C}({\it\omega}_{{\it\nu}}=0)$
, then
 $$\begin{eqnarray}\unicode[STIX]{x1D63C}_{0}=-\unicode[STIX]{x1D642}^{-1}\overline{\unicode[STIX]{x1D63C}}_{0}^{\text{T}}\unicode[STIX]{x1D642},\quad \unicode[STIX]{x1D642}=\text{i}\unicode[STIX]{x1D645},\ \unicode[STIX]{x1D645}=\left(\begin{array}{@{}cc@{}}0 & -1\\ 1 & 0\\ \end{array}\right),\end{eqnarray}$$
meaning that
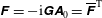 $\unicode[STIX]{x1D641}=-\text{i}\unicode[STIX]{x1D642}\unicode[STIX]{x1D63C}_{0}=\overline{\unicode[STIX]{x1D641}}^{\text{T}}$
is a Hermitian matrix:
 $$\begin{eqnarray}\unicode[STIX]{x1D641}=\left(\begin{array}{@{}cc@{}}2{\rm\Omega}(1+\mathit{Ro}) & \text{i}m{\rm\Omega}\\ -\text{i}m{\rm\Omega} & 2{\it\alpha}^{2}{\rm\Omega}\\ \end{array}\right).\end{eqnarray}$$
Then, the eigenvalue problem
 $\unicode[STIX]{x1D63C}_{0}\boldsymbol{w}=\text{i}{\it\omega}\boldsymbol{w}$
acquires the Hamiltonian form
 $$\begin{eqnarray}\unicode[STIX]{x1D641}\boldsymbol{w}=\text{i}{\it\omega}\unicode[STIX]{x1D645}\boldsymbol{w},\quad \unicode[STIX]{x1D641}=\overline{\unicode[STIX]{x1D641}}^{\text{T}}\end{eqnarray}$$
and has the eigenvalues
 ${\it\omega}_{1,2}=-m{\rm\Omega}\pm 2{\it\alpha}{\rm\Omega}\sqrt{1+\mathit{ Ro}}$
, corresponding to Kelvin waves.