1 Introduction
It is well known that high-frequency vibrations of a tank containing a fluid with free surface or two superimposed immiscible fluids can lead to very interesting and non-trivial effects. For example, the Rayleigh–Taylor instability of two superimposed fluids (with the heavier fluid on top of the lighter one) can be suppressed by vertical vibrations, and horizontal vibrations of the tank may lead to quasi-stationary finite-amplitude waves on the interface (see e.g. Wolf Reference Wolf1969, Reference Wolf1970; Lyubimov, Lyubimova & Cherepanov Reference Lyubimov, Lyubimova and Cherepanov2003). Other examples of non-trivial effects of vibrations include suppression of instability in liquid bridges (Benilov Reference Benilov2016), parametric resonance (Faraday waves) (e.g. Miles & Henderson Reference Miles and Henderson1990; Mancebo & Vega Reference Mancebo and Vega2002), steady streaming (e.g. Riley Reference Riley2001), vibrational convection (e.g. Zen’kovskaya & Simonenko Reference Zen’kovskaya and Simonenko1966; Gershuni & Lyubimov Reference Gershuni and Lyubimov1998), counterintuitive behaviour of solid particles in a vibrating fluid (e.g. Sennitskii Reference Sennitskii1985, Reference Sennitskii1999, Reference Sennitskii2007; Vladimirov Reference Vladimirov2005) and even a quantum-like behaviour of a droplet bouncing on the free surface of a vibrating fluid (see Couder et al. Reference Couder, Protiere, Fort and Boudaoud2005; Couder & Fort Reference Couder and Fort2006). Some possible applications of vibrating fluids can be found in Beysens (Reference Beysens2006).
Most relevant to the present paper is the stabilisation of an unstable equilibrium of a two-layer fluid (the Rayleigh–Taylor instability) by vertical vibrations of the container. This was observed experimentally by Wolf (Reference Wolf1969, Reference Wolf1970). A first theoretical treatment of the problem was done by Troyon & Gruber (Reference Troyon and Gruber1971) who considered the linearised stability problem and concluded that vibrational stabilisation is possible only if both surface tension and viscosity are present. The analysis of Troyon & Gruber (Reference Troyon and Gruber1971) was restricted to containers with relatively small aspect ratio (the horizontal size of the container is not larger than the depth of either fluid layer), and no physical mechanism of the stabilisation was proposed. In a relatively recent paper, Lapuerta, Mancebo & Vega (Reference Lapuerta, Mancebo and Vega2001) have considered the problem again and developed a weakly nonlinear theory of this phenomenon in the case when both the aspect ratio of the container and the vibration frequency are large. They have found that the stabilising effect of vibration is similar to the effect of surface tension and, because of that, the stabilisation may occur even for zero surface tension. As far as we know, this is the only earlier paper where the analogy between the effects of vibration and surface tension has been noticed.
In this paper, we are not concerned with the stabilisation of unstable equilibria, rather, we are interested in the effect of vibrations on the usual water waves. In particular, we want to understand the difference between the usual water waves and the waves in a vibrating fluid that makes the above-mentioned phenomena possible. So, we consider the simplest possible case of an infinite horizontal fluid layer of finite depth which is subject to high-frequency vertical vibrations. It is known that, under certain conditions, the dynamics of a periodically forced system can be described as a superposition of a fast oscillatory motion and a slowly varying averaged motion. In this case, it is possible to obtain averaged equations describing this slow evolution by employing a suitable averaging procedure (see e.g. Zen’kovskaya & Simonenko Reference Zen’kovskaya and Simonenko1966; Lyubimov et al. Reference Lyubimov, Lyubimova and Cherepanov2003; Yudovich Reference Yudovich2003). Here ‘slow’ means that the characteristic time scale for these waves is much longer than the period of vibrations, i.e.
 $$\begin{eqnarray}\unicode[STIX]{x1D714}\gg \sqrt{g/H},\end{eqnarray}$$
where
 $\unicode[STIX]{x1D714}$
is the vibration frequency,
 $H$
is the mean fluid depth and
 $g$
is the gravitational acceleration.
For the flow regimes considered here to be observable, one needs to make sure that there is no parametric instability leading to generation of Faraday waves (see e.g. Benjamin & Ursell Reference Benjamin and Ursell1954; Miles & Henderson Reference Miles and Henderson1990; Kumar & Tuckerman Reference Kumar and Tuckerman1994; Mancebo & Vega Reference Mancebo and Vega2002). The theory developed below works in the limit of very high vibration frequency (much higher than the frequency range where the parametric instability usually occurs). So, it will be assumed throughout the paper that either there is no parametric instability for some given values of the amplitude and frequency of the vibration or the instability is suppressed by some other factor (e.g. by viscosity).
The aim of this paper is to derive and analyse nonlinear shallow-water equations that describe slowly varying long waves on the surface of a vertically vibrating layer of an inviscid fluid. Similar, but more general, equations without the long-wave approximation had been derived earlier by Lyubimov et al. (Reference Lyubimov, Lyubimova and Cherepanov2003) and by Yudovich (Reference Yudovich2003). Somewhat similar averaged equations had also been obtained for more complicated systems, which involve not only a free surface, but also some additional physical effects, such as the Marangoni effect (see Zen’kovskaya, Novosyadlyi & Shleikel’ (Reference Zen’kovskaya, Novosyadlyi and Shleikel’2007) and references therein) or van der Waals forces between a rigid substrate and a liquid film (Shklyaev, Khenner & Alabuzhev Reference Shklyaev, Khenner and Alabuzhev2008; Shklyaev, Alabuzhev & Khenner Reference Shklyaev, Alabuzhev and Khenner2009). Here we focus on the pure effect of the vibration on free-surface flows. To make this effect as transparent as possible, we shall consider the simplest problem and completely ignore compressibility, viscosity and surface tension. As far as we are aware, long-wave asymptotic behaviour of a vibrating fluid layer in this simple situation has not been considered before.
Let us briefly discuss whether this simple problem can still be relevant for real flows. The assumption that sound waves can be ignored means that the typical hydrodynamic velocity is much smaller than the speed of sound
 $c$
, i.e.
 $$\begin{eqnarray}H\unicode[STIX]{x1D714}\ll c.\end{eqnarray}$$
The viscosity can be dropped if the viscous time scale is much greater than the typical period of the waves, i.e.
 $$\begin{eqnarray}H^{2}/\unicode[STIX]{x1D708}\gg \sqrt{H/g},\end{eqnarray}$$
where
 $\unicode[STIX]{x1D708}$
is the kinematic viscosity of the fluid. Note that (1.1) and (1.3) imply that the thickness of viscous boundary layers is much less than the fluid depth:
 $\sqrt{\unicode[STIX]{x1D708}/\unicode[STIX]{x1D714}}\ll H$
. Combining (1.1) and (1.2), we obtain
 $$\begin{eqnarray}\displaystyle \sqrt{g/H}\ll \unicode[STIX]{x1D714}\ll c/H. & & \displaystyle\end{eqnarray}$$
For a water layer of depth
 $10$
cm, this is equivalent to
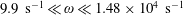 $9.9~\text{s}^{-1}\ll \unicode[STIX]{x1D714}\ll 1.48\times 10^{4}~\text{s}^{-1}$
, which gives us quite a wide range of
 $\unicode[STIX]{x1D714}$
(say, from
 $100~\text{s}^{-1}$
to
 $1000~\text{s}^{-1}$
). As was mentioned earlier, the effects of surface tension will not be considered for simplicity. This is a reasonable assumption provided that the Bond number, defined as
 $Bo=\unicode[STIX]{x1D70C}gH^{2}/\unicode[STIX]{x1D70E}$
(where
 $\unicode[STIX]{x1D70C}$
is the fluid density and
 $\unicode[STIX]{x1D70E}$
is the surface tension), is sufficiently large. For the water–air interface, the Bond number varies from
 $Bo\approx 1.34\times 10^{3}$
for the fluid depth
 $H=10$
cm to
 $Bo\approx 13.4$
for
 $H=1~\text{cm}$
, so that the surface tension can be safely dropped within this range. The effects of surface tension become important for
 $H\lesssim 0.5~\text{cm}$
. Surface tension will be discussed in more detail in appendix B.
The outline of the paper is as follows. Section 2 contains the formulation of the mathematical problem. In § 3, we derive a general averaged model without the long-wave approximation (although similar equations had been derived earlier by Lyubimov et al. (Reference Lyubimov, Lyubimova and Cherepanov2003) and Yudovich (Reference Yudovich2003), we include this case for the sake of completeness and because our approach is different from that of the above papers). The asymptotic equations are Hamiltonian, and the dispersion relation for small-amplitude waves suggests that the effect of the vibration is similar to that of surface tension. In § 4, we derive two long-wave asymptotic models: for the vibration amplitude much smaller than the fluid depth and for the vibration amplitude of the same order as the fluid depth. It turns out that these two physically different situations lead to the same asymptotic equations. In § 5, we consider one-dimensional waves governed by the equations derived in § 4. Here we show that the equations have travelling wave solutions in the form of both periodic and solitary waves. Finally, § 6 contains a discussion of the results.
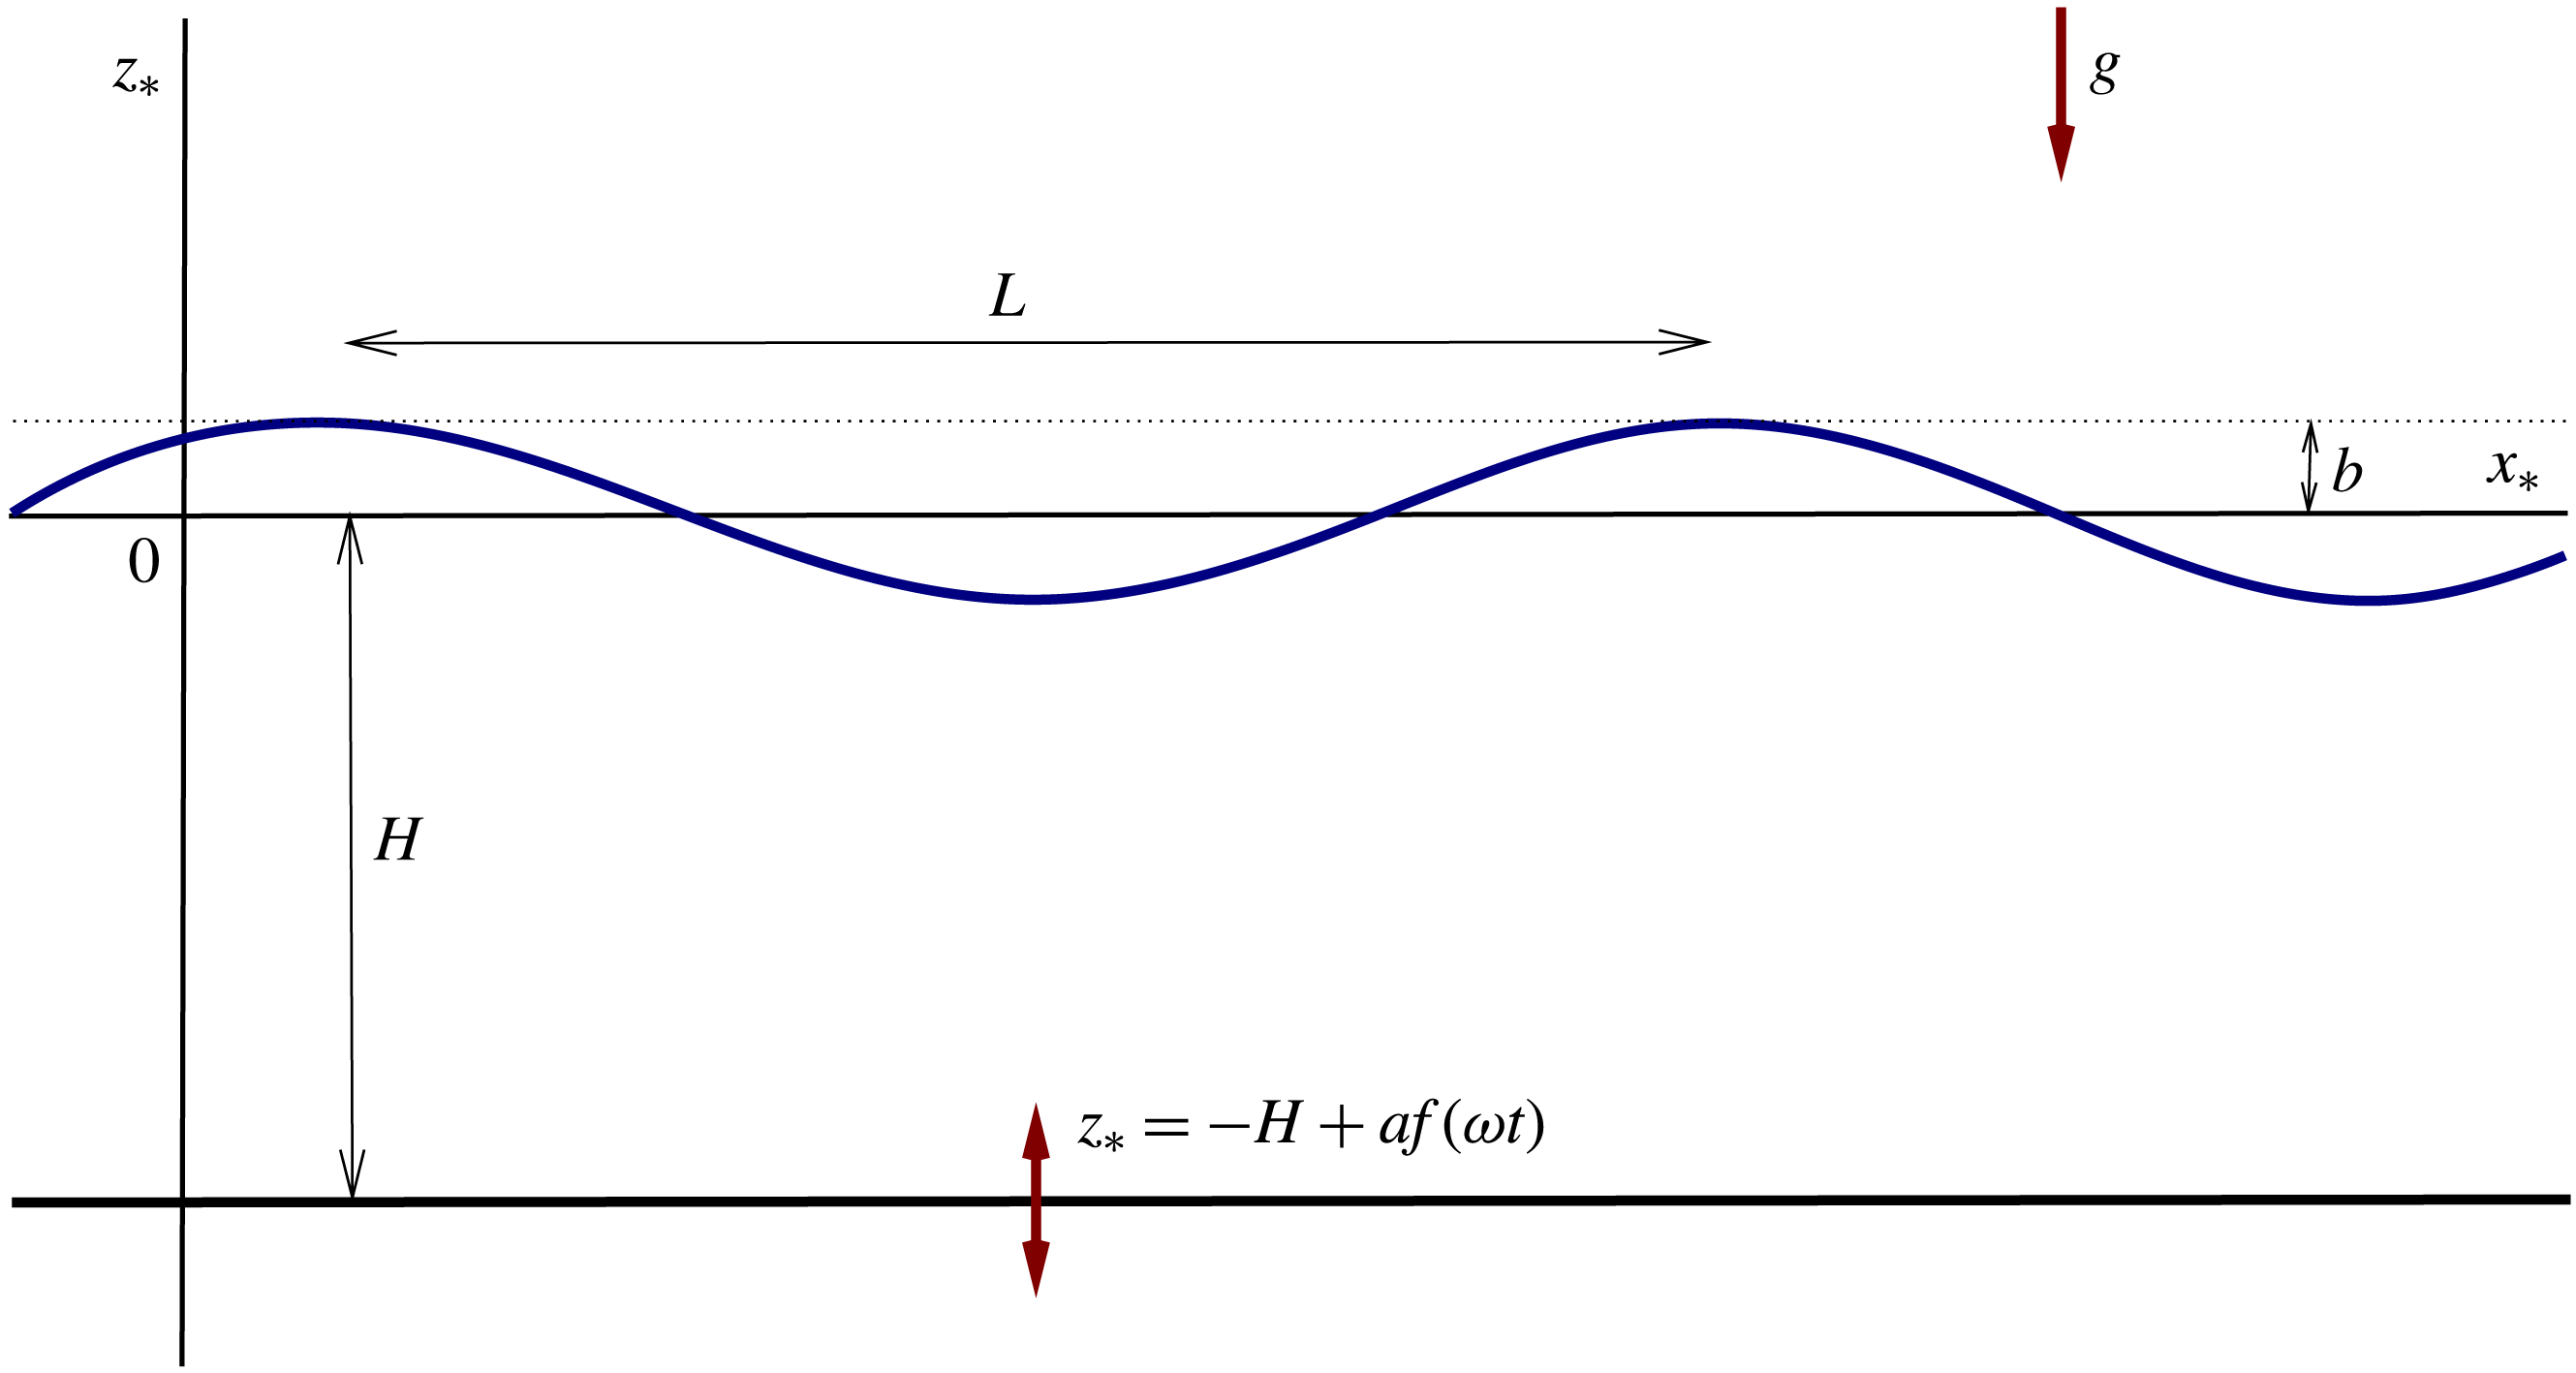
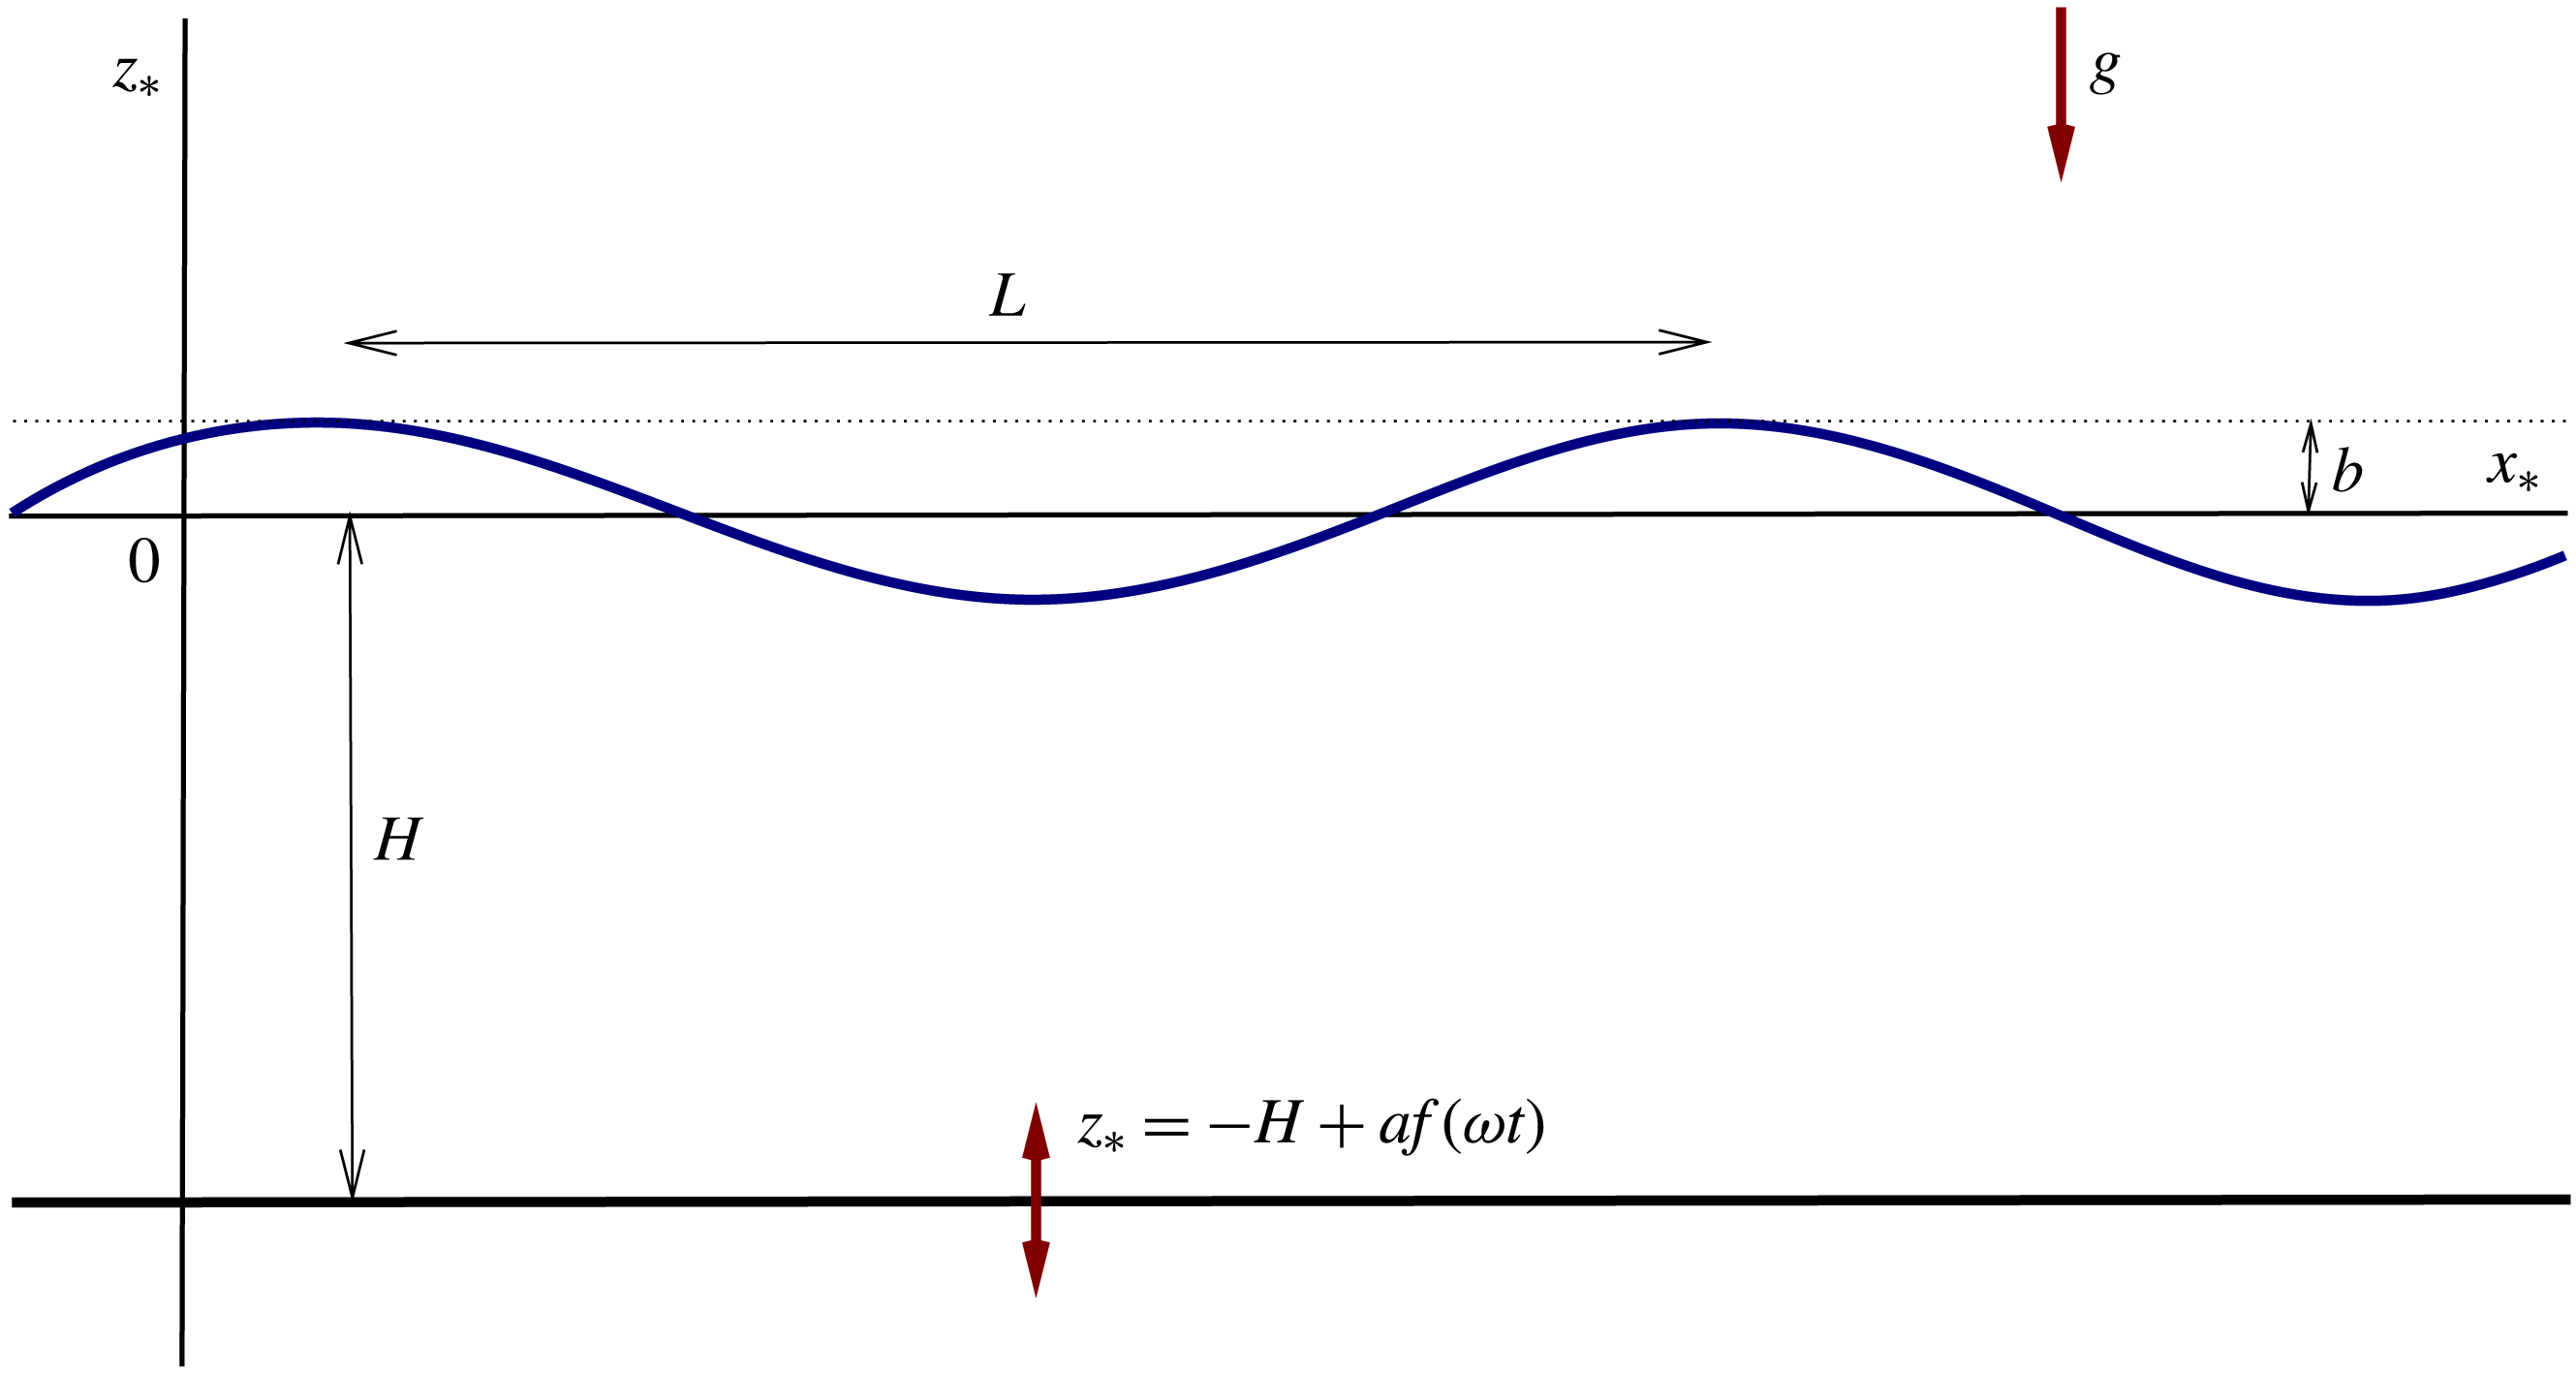
Sketch of the flow.
2 Basic equations
Consider an infinite layer of an inviscid fluid over a flat rigid bottom which vibrates in the vertical direction with amplitude
 $a$
and angular frequency
 $\unicode[STIX]{x1D714}$
(see figure 1). Relative to the reference frame fixed in space, the equation of the bottom is
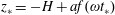 $z_{\ast }=-H+af(\unicode[STIX]{x1D714}t_{\ast })$
where
 $z_{\ast }$
is the vertical coordinate and
 $t_{\ast }$
is time.
In what follows we shall work in the frame of reference vibrating with the bottom. Relative to it, the flow domain is
 $$\begin{eqnarray}\displaystyle D_{\ast }=\{(x_{\ast },y_{\ast },z_{\ast })\in \mathbb{R}^{3}|-\infty <x_{\ast },y_{\ast }<\infty ,-H<z_{\ast }<\unicode[STIX]{x1D702}_{\ast }(x_{\ast },y_{\ast },t_{\ast })\}, & & \displaystyle\end{eqnarray}$$
where
 $x_{\ast }$
,
 $y_{\ast }$
and
 $z_{\ast }$
are Cartesian coordinates;
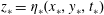 $z_{\ast }=\unicode[STIX]{x1D702}_{\ast }(x_{\ast },y_{\ast },t_{\ast })$
is the equation of the free surface. It is assumed that in the undisturbed state,
 $\unicode[STIX]{x1D702}_{\ast }(x_{\ast },y_{\ast },t_{\ast })=0$
.
Under the assumption that the flow is irrotational, the equations of motion and boundary conditions can be written as
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \unicode[STIX]{x1D6FB}_{\ast }^{2}\unicode[STIX]{x1D719}_{\ast }=0\quad \text{in }D_{\ast },\\ \displaystyle \unicode[STIX]{x2202}_{t_{\ast }}\unicode[STIX]{x1D719}_{\ast }+\frac{|\unicode[STIX]{x1D735}_{\ast }\unicode[STIX]{x1D719}_{\ast }|^{2}}{2}+(g+a\ddot{f})\unicode[STIX]{x1D702}_{\ast }=0\quad \text{at }z_{\ast }=\unicode[STIX]{x1D702}_{\ast }(x_{\ast },y_{\ast },t_{\ast }),\\ \displaystyle \unicode[STIX]{x2202}_{t_{\ast }}\unicode[STIX]{x1D702}_{\ast }+\unicode[STIX]{x2202}_{x_{\ast }}\unicode[STIX]{x1D719}_{\ast }\unicode[STIX]{x2202}_{x_{\ast }}\unicode[STIX]{x1D702}_{\ast }+\unicode[STIX]{x2202}_{y_{\ast }}\unicode[STIX]{x1D719}_{\ast }\unicode[STIX]{x2202}_{y_{\ast }}\unicode[STIX]{x1D702}_{\ast }=\unicode[STIX]{x2202}_{z_{\ast }}\unicode[STIX]{x1D719}_{\ast }\quad \text{at }z_{\ast }=\unicode[STIX]{x1D702}_{\ast }(x_{\ast },y_{\ast },t_{\ast }),\\ \displaystyle \unicode[STIX]{x2202}_{z_{\ast }}\unicode[STIX]{x1D719}_{\ast }=0\quad \text{at }z_{\ast }=-H,\end{array}\right\} & & \displaystyle\end{eqnarray}$$
where
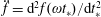 $\ddot{f}=\text{d}^{2}f(\unicode[STIX]{x1D714}t_{\ast })/\text{d}t_{\ast }^{2}$
,
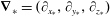 $\unicode[STIX]{x1D735}_{\ast }=(\unicode[STIX]{x2202}_{x_{\ast }},\unicode[STIX]{x2202}_{y_{\ast }},\unicode[STIX]{x2202}_{z_{\ast }})$
. We shall assume that either
 $\unicode[STIX]{x1D719}_{\ast }$
and
 $\unicode[STIX]{x1D702}_{\ast }$
are periodic in
 $x_{\ast }$
and
 $y_{\ast }$
or some conditions at infinity are imposed (e.g.
 $\unicode[STIX]{x1D719}_{\ast }\rightarrow 0$
and
 $\unicode[STIX]{x1D702}_{\ast }\rightarrow 0$
as
 $\sqrt{x_{\ast }^{2}+y_{\ast }^{2}}\rightarrow \infty$
).
Now we introduce the dimensionless variables
 $x,y,z,\unicode[STIX]{x1D70F},\unicode[STIX]{x1D719},\unicode[STIX]{x1D702}$
defined as
 $$\begin{eqnarray}\displaystyle x_{\ast }=Lx,\quad y_{\ast }=Ly,\quad z_{\ast }=Hz,\quad \unicode[STIX]{x1D70F}=\unicode[STIX]{x1D714}t_{\ast },\quad \unicode[STIX]{x1D719}_{\ast }=a\unicode[STIX]{x1D714}H\unicode[STIX]{x1D719},\quad \unicode[STIX]{x1D702}_{\ast }=b\unicode[STIX]{x1D702}. & & \displaystyle\end{eqnarray}$$
Here
 $L$
is the characteristic length scale in the horizontal direction,
 $H$
is the depth of the layer in the undisturbed state and
 $b$
is the characteristic scale for the displacement of the free surface from its undisturbed position.
In the dimensionless variables, the above equations take the form
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{zz}+\unicode[STIX]{x1D707}^{2}(\unicode[STIX]{x1D719}_{xx}+\unicode[STIX]{x1D719}_{yy})=0\quad \text{in }D, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D6FC}\left(\unicode[STIX]{x1D707}^{2}\frac{\unicode[STIX]{x1D719}_{x}^{2}+\unicode[STIX]{x1D719}_{y}^{2}}{2}+\frac{\unicode[STIX]{x1D719}_{z}^{2}}{2}\right)+\unicode[STIX]{x1D6FD}[\unicode[STIX]{x1D6FE}+f^{\prime \prime }(\unicode[STIX]{x1D70F})]\unicode[STIX]{x1D702}=0\quad \text{at }z=\unicode[STIX]{x1D6FD}\unicode[STIX]{x1D702}(x,y,\unicode[STIX]{x1D70F}). & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}_{\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D707}^{2}(\unicode[STIX]{x1D719}_{x}\unicode[STIX]{x1D702}_{x}+\unicode[STIX]{x1D719}_{y}\unicode[STIX]{x1D702}_{y})=\frac{\unicode[STIX]{x1D6FC}}{\unicode[STIX]{x1D6FD}}\unicode[STIX]{x1D719}_{z}\quad \text{at }z=\unicode[STIX]{x1D6FD}\unicode[STIX]{x1D702}(x,y,\unicode[STIX]{x1D70F}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{z}=0\quad \text{at }z=-1, & \displaystyle\end{eqnarray}$$
where
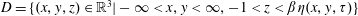 $D=\{(x,y,z)\in \mathbb{R}^{3}|-\infty <x,y<\infty ,-1<z<\unicode[STIX]{x1D6FD}\unicode[STIX]{x1D702}(x,y,\unicode[STIX]{x1D70F})\}$
;
 $\unicode[STIX]{x1D6FC}$
,
 $\unicode[STIX]{x1D6FD}$
,
 $\unicode[STIX]{x1D6FE}$
and
 $\unicode[STIX]{x1D707}$
are dimensionless parameters defined as
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D6FC}=\frac{a}{H},\quad \unicode[STIX]{x1D6FD}=\frac{b}{H},\quad \unicode[STIX]{x1D6FE}=\frac{g}{a\unicode[STIX]{x1D714}^{2}},\quad \unicode[STIX]{x1D707}=\frac{H}{L}, & & \displaystyle\end{eqnarray}$$
so that
 $\unicode[STIX]{x1D6FC}$
is the dimensionless amplitude of the vibrations,
 $\unicode[STIX]{x1D6FD}$
the dimensionless amplitude of the free-surface waves,
 $\unicode[STIX]{x1D6FE}$
the ratio of the gravitational acceleration to the acceleration due to the vibrations and
 $\unicode[STIX]{x1D707}$
is the standard long-wave parameter (the ratio of the fluid depth to the wavelength).
In what follows we deal with waves of finite amplitude corresponding to
 $\unicode[STIX]{x1D6FD}=1$
. We shall consider two cases: mean flows with
 $\unicode[STIX]{x1D707}=1$
and with
 $\unicode[STIX]{x1D707}\ll 1$
(long-wave approximation).
3 Slow motions without long-wave approximation
Let
 $\unicode[STIX]{x1D707}=1$
and
 $$\begin{eqnarray}\unicode[STIX]{x1D6FC}=\unicode[STIX]{x1D716},\quad \unicode[STIX]{x1D6FD}=1,\quad \unicode[STIX]{x1D6FE}=\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D716},\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6FE}_{0}$
is a constant of order 1 (i.e.
 $\unicode[STIX]{x1D6FE}_{0}=O(1)$
as
 $\unicode[STIX]{x1D716}\rightarrow 0$
). These assumptions imply that (i) the amplitude of vibrations of the bottom is small in comparison with the fluid depth, (ii) the amplitude of the waves may be of the same order of magnitude as the fluid depth and (iii) the frequency of vibrations is sufficiently high, so that the acceleration due to vibrations is much greater than the gravitational acceleration.
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D719}=0\quad \text{in }D, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{\unicode[STIX]{x1D70F}}+f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}+\unicode[STIX]{x1D716}\left(\frac{|\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D702}\right)=0\quad \text{at }z=\unicode[STIX]{x1D702}(x,y,\unicode[STIX]{x1D70F}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}_{\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D716}\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D702}=\unicode[STIX]{x1D716}\unicode[STIX]{x1D719}_{z}\quad \text{at }z=\unicode[STIX]{x1D702}(x,y,\unicode[STIX]{x1D70F}). & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{z}=0\quad \text{at }z=-1. & \displaystyle\end{eqnarray}$$
Here
 $\unicode[STIX]{x1D735}=(\unicode[STIX]{x2202}_{x},\unicode[STIX]{x2202}_{y},\unicode[STIX]{x2202}_{z})$
is the gradient in three dimensions and
 $\unicode[STIX]{x1D735}_{\shortparallel }=(\unicode[STIX]{x2202}_{x},\unicode[STIX]{x2202}_{y})$
is the two-dimensional gradient (parallel to the bottom). As was mentioned above, these equations should be supplemented with an additional condition which will be either a periodicity in variables
 $x$
and
 $y$
or a condition on the behaviour of the solution at infinity (as
 $\sqrt{x^{2}+y^{2}}\rightarrow \infty$
). This condition will be specified later (if it is needed).
3.1 Derivation of the asymptotic equations
We are interested in the behaviour of solutions of (3.2)–(3.5) in the limit
 $\unicode[STIX]{x1D716}\rightarrow 0$
. To construct an asymptotic expansion of a solution, we employ the method of multiple scales (e.g. Nayfeh Reference Nayfeh1973) and assume that the expansion has a form
 $$\begin{eqnarray}\unicode[STIX]{x1D719}=\unicode[STIX]{x1D719}_{0}(x,y,z,\unicode[STIX]{x1D70F},t)+\unicode[STIX]{x1D716}\unicode[STIX]{x1D719}_{1}(x,y,z,\unicode[STIX]{x1D70F},t)+\cdots \,,\quad \unicode[STIX]{x1D702}=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t)+\unicode[STIX]{x1D716}\unicode[STIX]{x1D702}_{1}(x,y,\unicode[STIX]{x1D70F},t)+\cdots\end{eqnarray}$$
where
 $$\begin{eqnarray}\displaystyle t=\unicode[STIX]{x1D716}\unicode[STIX]{x1D70F} & & \displaystyle\end{eqnarray}$$
is the slow time. On substituting these in (3.2)–(3.5) and collecting terms of the same order in
 $\unicode[STIX]{x1D716}$
, we obtain
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D719}_{0}=0\quad \text{in }D_{0}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{0\unicode[STIX]{x1D70F}}+f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{0}=0\quad \text{at }z=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{0z}=0\quad \text{at }z=-1, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}_{0\unicode[STIX]{x1D70F}}=0 & \displaystyle\end{eqnarray}$$
at leading order and
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D719}_{1}=0\quad \text{in }D_{0}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{1\unicode[STIX]{x1D70F}}+f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{1}+\unicode[STIX]{x1D719}_{0z\unicode[STIX]{x1D70F}}\unicode[STIX]{x1D702}_{1}+\unicode[STIX]{x1D719}_{0t}+\frac{|\unicode[STIX]{x1D6FB}\unicode[STIX]{x1D719}_{0}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D702}_{0}=0\quad \text{at }z=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{1z}=0\quad \text{at }z=-1. & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}_{1\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D702}_{0t}+\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D702}_{0}=\unicode[STIX]{x1D719}_{0z}\quad \text{at }z=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t) & \displaystyle\end{eqnarray}$$
at first order. Here
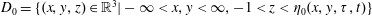 $D_{0}=\{(x,y,z)\in \mathbb{R}^{3}|-\infty <x,y<\infty ,-1<z<\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t)\}$
.
Throughout the paper, we shall use the following fact: any bounded
 $2\unicode[STIX]{x03C0}$
-periodic function
 $g(\unicode[STIX]{x1D70F})$
can be presented in the form
 $$\begin{eqnarray}\displaystyle g(\unicode[STIX]{x1D70F})=\overline{g}+\tilde{g}(\unicode[STIX]{x1D70F}), & & \displaystyle\end{eqnarray}$$
where
 $$\begin{eqnarray}\displaystyle \overline{g}=\frac{1}{2\unicode[STIX]{x03C0}}\int _{0}^{2\unicode[STIX]{x03C0}}g(\unicode[STIX]{x1D70F})\,\text{d}\unicode[STIX]{x1D70F} & & \displaystyle\end{eqnarray}$$
is the averaged part of
 $g(\unicode[STIX]{x1D70F})$
and
 $\tilde{g}(\unicode[STIX]{x1D70F})=g(\unicode[STIX]{x1D70F})-\overline{g}$
is its oscillatory part (having zero mean).
Consider now the leading-order equations (3.8)–(3.11). It follows from (3.11) that
 $\unicode[STIX]{x1D702}_{0}$
does not depend on the fast time, i.e.
 $$\begin{eqnarray}\unicode[STIX]{x1D702}_{0}=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t).\end{eqnarray}$$
Note that this equation implies that
 $D_{0}$
does not depend on the fast time
 $\unicode[STIX]{x1D70F}$
, i.e.
 $D_{0}$
is the domain corresponding to the averaged (over the period in
 $\unicode[STIX]{x1D70F}$
) position of the free surface.
Substituting (3.18) into (3.9) and separating the oscillatory part, we find that
 $$\begin{eqnarray}\tilde{\unicode[STIX]{x1D719}}_{0}(x,y,z,t,\unicode[STIX]{x1D70F})=-f^{\prime }(\unicode[STIX]{x1D70F})\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t)\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t).\end{eqnarray}$$
The oscillatory parts of (3.8) and (3.10) yield
 $$\begin{eqnarray}\unicode[STIX]{x1D6FB}^{2}\tilde{\unicode[STIX]{x1D719}}_{0}=0\quad \text{in }D_{0}\end{eqnarray}$$
and
 $$\begin{eqnarray}\tilde{\unicode[STIX]{x1D719}}_{0z}=0\quad \text{at }z=-1.\end{eqnarray}$$
If function
 $\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t)$
were known, we would be able to find
 $\tilde{\unicode[STIX]{x1D719}}_{0}$
by solving the Laplace equation (3.20) subject to the boundary conditions (3.19) and (3.21) and the periodicity or decay condition in
 $x$
and
 $y$
.
Consider now the first-order equations (3.12)–(3.15). On averaging (3.13) and (3.15), we obtain
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x2202}_{t}\overline{\unicode[STIX]{x1D719}}_{0}+\overline{f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{1}}+\overline{(\unicode[STIX]{x2202}_{\unicode[STIX]{x1D70F}}\unicode[STIX]{x2202}_{z}\unicode[STIX]{x1D719}_{0})\unicode[STIX]{x1D702}_{1}}+\frac{\overline{|\unicode[STIX]{x1D6FB}\unicode[STIX]{x1D719}_{0}|^{2}}}{2}+\unicode[STIX]{x1D6FE}_{0}\overline{\unicode[STIX]{x1D702}}_{0}=0\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x2202}_{t}\overline{\unicode[STIX]{x1D702}}_{0}+\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D719}}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}=\unicode[STIX]{x2202}_{z}\overline{\unicode[STIX]{x1D719}}_{0}\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t). & \displaystyle\end{eqnarray}$$
Note that
 $$\begin{eqnarray}\displaystyle \overline{|\unicode[STIX]{x1D6FB}\unicode[STIX]{x1D719}_{0}|^{2}}=|\unicode[STIX]{x1D6FB}\overline{\unicode[STIX]{x1D719}}_{0}|^{2}+\overline{|\unicode[STIX]{x1D6FB}\tilde{\unicode[STIX]{x1D719}}_{0}|^{2}},\quad \overline{f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{1}}=-\overline{f^{\prime }(\unicode[STIX]{x1D70F})\tilde{\unicode[STIX]{x1D702}}_{1\unicode[STIX]{x1D70F}}} & & \displaystyle\end{eqnarray}$$
and
 $$\begin{eqnarray}\displaystyle \overline{(\unicode[STIX]{x2202}_{\unicode[STIX]{x1D70F}}\unicode[STIX]{x2202}_{z}\unicode[STIX]{x1D719}_{0})\unicode[STIX]{x1D702}_{1}}=-\overline{(\unicode[STIX]{x2202}_{z}\tilde{\unicode[STIX]{x1D719}}_{0})\unicode[STIX]{x2202}_{\unicode[STIX]{x1D70F}}\tilde{\unicode[STIX]{x1D702}}_{1}}. & & \displaystyle\end{eqnarray}$$
So, (3.22) can be written as
 $$\begin{eqnarray}\unicode[STIX]{x2202}_{t}\overline{\unicode[STIX]{x1D719}}_{0}+\frac{|\unicode[STIX]{x1D6FB}\overline{\unicode[STIX]{x1D719}}_{0}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\overline{\unicode[STIX]{x1D702}}_{0}=G(x,y,t)\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t),\end{eqnarray}$$
where
 $$\begin{eqnarray}G(x,y,t)=\overline{f^{\prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x2202}_{\unicode[STIX]{x1D70F}}\tilde{\unicode[STIX]{x1D702}}_{1}}+\overline{(\unicode[STIX]{x2202}_{z}\tilde{\unicode[STIX]{x1D719}}_{0})\unicode[STIX]{x2202}_{\unicode[STIX]{x1D70F}}\tilde{\unicode[STIX]{x1D702}}_{1}}-\frac{\overline{|\unicode[STIX]{x1D6FB}\tilde{\unicode[STIX]{x1D719}}_{0}|^{2}}}{2}\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t).\end{eqnarray}$$
Equation (3.26) implicitly depends on both
 $\tilde{\unicode[STIX]{x1D719}}_{0}$
and
 $\tilde{\unicode[STIX]{x1D702}}_{1}$
, which appear in (3.27). Function
 $\tilde{\unicode[STIX]{x1D702}}_{1}(x,y,\unicode[STIX]{x1D70F},t)$
can be found from the oscillatory part of (3.15) that can be written as
 $$\begin{eqnarray}\tilde{\unicode[STIX]{x1D702}}_{1\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D735}_{\shortparallel }\tilde{\unicode[STIX]{x1D719}}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}=\unicode[STIX]{x2202}_{z}\tilde{\unicode[STIX]{x1D719}}_{0}\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t),\end{eqnarray}$$
and this equation can be solved once
 $\tilde{\unicode[STIX]{x1D719}}_{0}$
is known.
It follows from (3.19)–(3.21) that
 $\tilde{\unicode[STIX]{x1D719}}_{0}(x,y,z,\unicode[STIX]{x1D70F},t)$
can be written in the form
 $$\begin{eqnarray}\tilde{\unicode[STIX]{x1D719}}_{0}(x,y,z,\unicode[STIX]{x1D70F},t)=-\unicode[STIX]{x1D6F7}(x,y,z,t)f^{\prime }(\unicode[STIX]{x1D70F}),\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6F7}$
is a solution of the following boundary-value problem:
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D6F7}=0\quad \text{for }-\infty <x,y<\infty ,-1<z<\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6F7}_{z}=0\quad \text{at }z=-1, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6F7}=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t)\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t), & \displaystyle\end{eqnarray}$$
subject to (yet unspecified) additional conditions in variables
 $x$
and
 $y$
(periodicity or decay at infinity). Suppose that we can solve problem (3.30)–(3.32) and let
 $\unicode[STIX]{x1D6F7}(x,y,z,t)$
be its solution. Evidently, it will depend on
 $\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t)$
. In what follows, we will use the following notation
 $$\begin{eqnarray}\unicode[STIX]{x1D6F7}_{z}|_{z=\overline{\unicode[STIX]{x1D702}}_{0}}=\hat{Q}(x,y,t).\end{eqnarray}$$
It follows from (3.28)–(3.33) that
 $$\begin{eqnarray}\displaystyle & \displaystyle \overline{f^{\prime }\unicode[STIX]{x2202}_{\unicode[STIX]{x1D70F}}\tilde{\unicode[STIX]{x1D702}}_{1}}=-\overline{{f^{\prime }}^{2}}(\hat{Q}-(1-\hat{Q})|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}|^{2}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \overline{(\unicode[STIX]{x2202}_{z}\tilde{\unicode[STIX]{x1D719}}_{0})\unicode[STIX]{x2202}_{\unicode[STIX]{x1D70F}}\tilde{\unicode[STIX]{x1D702}}_{1}}=\overline{{f^{\prime }}^{2}}(\hat{Q}^{2}-\hat{Q}(1-\hat{Q})|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}|^{2}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \overline{|\unicode[STIX]{x1D6FB}\tilde{\unicode[STIX]{x1D719}}_{0}|^{2}}=\overline{{f^{\prime }}^{2}}(\hat{Q}^{2}+(1-\hat{Q})^{2}|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}|^{2}). & \displaystyle\end{eqnarray}$$
On substituting these into (3.27), we obtain
 $$\begin{eqnarray}G=\unicode[STIX]{x1D718}\left[\frac{\hat{Q}^{2}}{2}-\hat{Q}+\frac{1}{2}(1-\hat{Q})^{2}|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}|^{2}\right],\end{eqnarray}$$
where
 $$\begin{eqnarray}\unicode[STIX]{x1D718}=\overline{{f^{\prime }}^{2}}.\end{eqnarray}$$
Parameter
 $\unicode[STIX]{x1D718}$
will be referred to as the vibrational parameter. In the absence of vibration,
 $\unicode[STIX]{x1D718}=0$
. For the harmonic vibration in the form
 $f(\unicode[STIX]{x1D70F})=\cos \unicode[STIX]{x1D70F}$
,
 $\unicode[STIX]{x1D718}=1/2$
.
Finally, averaging (3.8) and (3.10), we get
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6FB}^{2}\overline{\unicode[STIX]{x1D719}}_{0}=0\quad \text{in }D_{0}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \overline{\unicode[STIX]{x1D719}}_{0z}=0\quad \text{at }z=-1. & \displaystyle\end{eqnarray}$$
Equations (3.39), (3.40), (3.23) and (3.26) with
 $G$
given by (3.37) represent a closed system of equations governing slow evolution of waves on the free surface of a vibrating fluid.
3.2 Some properties of the asymptotic equations
Let
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D701}=\overline{\unicode[STIX]{x1D702}}_{0},\quad \unicode[STIX]{x1D713}=\overline{\unicode[STIX]{x1D719}}_{0}. & & \displaystyle\end{eqnarray}$$
Then the averaged equations (3.23) and (3.26) can be written as
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D713}_{t}+\frac{|\unicode[STIX]{x1D6FB}\unicode[STIX]{x1D713}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D701}=\unicode[STIX]{x1D718}\left[\frac{\hat{Q}^{2}}{2}-\hat{Q}+\frac{1}{2}(1-\hat{Q})^{2}|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}|^{2}\right]\quad \text{at }z=\unicode[STIX]{x1D701}(x,y,t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D701}_{t}+\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}=\unicode[STIX]{x1D713}_{z}\quad \text{at }z=\unicode[STIX]{x1D701}(x,y,t), & \displaystyle\end{eqnarray}$$
where
 $\unicode[STIX]{x1D713}$
satisfies
 $$\begin{eqnarray}\unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D713}=0\quad \text{for }-1<z<\unicode[STIX]{x1D701}(x,y,t)\text{ and }\unicode[STIX]{x1D713}_{z}|_{z=-1}=0\end{eqnarray}$$
and where
 $$\begin{eqnarray}\hat{Q}=\unicode[STIX]{x1D6F7}_{z}|_{z=\unicode[STIX]{x1D701}(x,y,t)}\end{eqnarray}$$
and
 $\unicode[STIX]{x1D6F7}(x,y,z,t)$
is the solution of the problem
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D6F7}=0\quad \text{for }-\infty <x,y<\infty ,-1<z<\unicode[STIX]{x1D701}(x,y,t),\\ \displaystyle \unicode[STIX]{x1D6F7}_{z}|_{z=-1}=0,\quad \unicode[STIX]{x1D6F7}|_{z=\unicode[STIX]{x1D701}(x,y,t)}=\unicode[STIX]{x1D701}(x,y,t).\end{array}\right\} & & \displaystyle\end{eqnarray}$$
If there is no vibration, (3.42)–(3.44) reduce to the standard system of equations for irrotational water waves in a non-vibrating fluid. The vibration leads to the appearance of the extra term on the right-hand side of (3.42).
Equations (3.42)–(3.46) conserve the energy, given by
 $$\begin{eqnarray}H=\int _{{\mathcal{D}}}\,\text{d}x\,\text{d}y\int _{-1}^{\unicode[STIX]{x1D701}}\,\text{d}z\left[\frac{|\unicode[STIX]{x1D6FB}\unicode[STIX]{x1D713}|^{2}}{2}+\unicode[STIX]{x1D718}\frac{|\unicode[STIX]{x1D6FB}\unicode[STIX]{x1D6F7}|^{2}}{2}\right]+\int _{{\mathcal{D}}}\,\text{d}x\,\text{d}y\unicode[STIX]{x1D6FE}_{0}\frac{\unicode[STIX]{x1D701}^{2}}{2}.\end{eqnarray}$$
Here the domain of integration
 ${\mathcal{D}}$
is either the rectangle of periods, if periodic (in
 $x$
and
 $y$
) solutions are considered, or the whole plane
 $\mathbb{R}^{2}$
. In the latter case, it is assumed that
 $\unicode[STIX]{x1D713}$
,
 $\unicode[STIX]{x1D6F7}$
and
 $\unicode[STIX]{x1D701}$
decay at infinity so that the integrals in (3.47) exist.
Equations (3.42), (3.43) can be written in Hamiltonian form. If, following Zakharov (Reference Zakharov1968) (see also Miles Reference Miles1981), we introduce function
 $$\begin{eqnarray}\unicode[STIX]{x1D712}(x,y,t)\equiv \unicode[STIX]{x1D713}(x,y,z,t)|_{z=\unicode[STIX]{x1D701}(x,y,t)},\end{eqnarray}$$
then
 $\unicode[STIX]{x1D713}(x,y,z,t)$
is uniquely determined by
 $\unicode[STIX]{x1D712}(x,y,t)$
as a solution of the problem
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \unicode[STIX]{x1D6FB}^{2}\unicode[STIX]{x1D713}=0\quad \text{for }-\infty <x,y<\infty ,-1<z<\unicode[STIX]{x1D701}(x,y,t),\\ \displaystyle \unicode[STIX]{x1D713}_{z}|_{z=-1}=0,\quad \unicode[STIX]{x1D713}|_{z=\unicode[STIX]{x1D701}(x,y,t)}=\unicode[STIX]{x1D712}(x,y,t)\end{array}\right\} & & \displaystyle\end{eqnarray}$$
supplemented with appropriate boundary conditions in variables
 $x$
and
 $y$
.
It is also convenient to introduce the following notation
 $$\begin{eqnarray}\displaystyle \hat{N}(x,y,t)=\unicode[STIX]{x1D713}_{z}|_{z=\unicode[STIX]{x1D701}(x,y,t)}, & & \displaystyle\end{eqnarray}$$
where
 $\unicode[STIX]{x1D713}(x,y,z,t)$
is a solution of problem (3.49). Note that
 $\hat{N}(x,y,t)$
is uniquely determined by
 $\unicode[STIX]{x1D712}(x,y,t)$
.
To rewrite (3.42), (3.43) in terms of
 $\unicode[STIX]{x1D712}$
and
 $\unicode[STIX]{x1D701}$
, we first observe that
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \unicode[STIX]{x1D712}_{t}=\unicode[STIX]{x1D713}_{t}|_{z=\unicode[STIX]{x1D701}}+\hat{N}\unicode[STIX]{x1D701}_{t},\\ \displaystyle \unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D712}=\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}|_{z=\unicode[STIX]{x1D701}}+\hat{N}\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}.\end{array}\right\} & & \displaystyle\end{eqnarray}$$
Then, we use these to eliminate
 $\unicode[STIX]{x1D713}_{t}|_{z=\unicode[STIX]{x1D701}}$
and
 $\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}|_{z=\unicode[STIX]{x1D701}}$
from (3.42), (3.43). As a result, we obtain
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D712}_{t} & = & \displaystyle \hat{N}[\hat{N}-\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}\boldsymbol{\cdot }(\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D712}-\hat{N}\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701})]-\frac{\hat{N}^{2}}{2}\nonumber\\ \displaystyle & & \displaystyle -\,\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D712}-\hat{N}\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}|^{2}}{2}-\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D701}+\unicode[STIX]{x1D718}\left[\frac{\hat{Q}^{2}}{2}-\hat{Q}+\frac{1}{2}(1-\hat{Q})^{2}|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}|^{2}\right],\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D701}_{t} & = & \displaystyle \hat{N}-\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}\boldsymbol{\cdot }(\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D712}-\hat{N}\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}).\end{eqnarray}$$
It can be verified by direct calculation that (3.52)–(3.53) are equivalent to the canonical Hamiltonian equations
 $$\begin{eqnarray}\unicode[STIX]{x1D701}_{t}=\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D712}},\quad \unicode[STIX]{x1D712}_{t}=-\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}.\end{eqnarray}$$
Remark 1. If instead of
 $\unicode[STIX]{x1D6FE}=\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D716}$
, we consider
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D6FE}=\unicode[STIX]{x1D6E4}\unicode[STIX]{x1D716}^{2}, & & \displaystyle\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6E4}=O(1)$
as
 $\unicode[STIX]{x1D716}\rightarrow 0$
, then the last term (containing
 $\unicode[STIX]{x1D6FE}_{0}$
) on the left-hand side of (3.26) will not be present in the equation. This case corresponds to stronger vibrations when the gravitational acceleration is so small in comparison with the vibrational acceleration that the gravity effect is negligible even for slow motions.
Remark 2. One can consider small-amplitude waves and linearise (3.42)–(3.46). For waves in the form
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D701}=\text{Re}(\hat{\unicode[STIX]{x1D701}}\text{e}^{\text{i}(\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}-\unicode[STIX]{x1D714}t)}),\quad \overline{\unicode[STIX]{x1D719}}_{0}=\text{Re}(\hat{\unicode[STIX]{x1D713}}(z)\text{e}^{\text{i}(\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}-\unicode[STIX]{x1D714}t)}), & & \displaystyle\end{eqnarray}$$
where
 $\boldsymbol{k}=(k_{1},k_{2})$
, the dispersion relation has the form
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D714}^{2}(\boldsymbol{k})=|\boldsymbol{k}|\tanh (|\boldsymbol{k}|)[\unicode[STIX]{x1D6FE}_{0}+\unicode[STIX]{x1D718}|\boldsymbol{k}|\tanh (|\boldsymbol{k}|)]. & & \displaystyle\end{eqnarray}$$
If the vibrational parameter
 $\unicode[STIX]{x1D718}$
is zero, this reduces to the standard dispersion relation for the surface gravity waves on a fluid layer of finite depth. If function
 $\tanh (|\boldsymbol{k}|)$
that appears in the square brackets were replaced by
 $|\boldsymbol{k}|$
, the above dispersion relation would coincide with the dispersion relation for gravity–capillary waves with
 $\unicode[STIX]{x1D718}$
playing the role of surface tension. For long waves (
 $|\boldsymbol{k}|\ll 1$
), the dispersion relation reduces to
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D714}^{2}(\boldsymbol{k})=|\boldsymbol{k}|^{2}[\unicode[STIX]{x1D6FE}_{0}+(\unicode[STIX]{x1D718}-\unicode[STIX]{x1D6FE}_{0}/3)|\boldsymbol{k}|^{2}+O(|\boldsymbol{k}|^{4})], & & \displaystyle\end{eqnarray}$$
which, again, is the same as the long-wave limit of the dispersion relation for gravity–capillary waves. Therefore, it is natural to expect that the effect of the vibration is similar to that of surface tension at least for sufficiently long waves.
It is interesting that, in the short-wave limit (
 $|\boldsymbol{k}|\gg 1$
), the dispersion relation simplifies to
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D714}^{2}(\boldsymbol{k})=\unicode[STIX]{x1D6FE}_{0}|\boldsymbol{k}|+\unicode[STIX]{x1D718}|\boldsymbol{k}|^{2}+O(|\boldsymbol{k}|^{2}e^{-2|\boldsymbol{k}|}). & & \displaystyle\end{eqnarray}$$
This would be the same as the dispersion relation for gravity–capillary waves on deep water, if
 $|\boldsymbol{k}|^{2}$
in the second term were replaced by
 $|\boldsymbol{k}|^{3}$
. Note also that for sufficiently large
 $|\boldsymbol{k}|$
, the first term in the above formula is small in comparison with the second one. If it is discarded, we obtain non-dispersive waves.
4 Slow motions in the long-wave approximation
Consider now the situation when
 $\unicode[STIX]{x1D707}\ll 1$
. We shall derive two asymptotic models. In the first model, the amplitude of the vibrations is assumed to be small compared with the fluid depth, while in the second, it is of the same order as the fluid depth. We shall see that, surprisingly, both assumptions lead to the same asymptotic equations.
4.1 Small-amplitude vibrations
The long-wave model discussed in this subsection can be obtained directly from (2.4)–(2.7). However, it is much easier to derive asymptotic equations from the averaged equations of § 3, and this is what we shall do now.
One of the standard recipes to derive the shallow-water equations is to re-scale the independent variables
 $x$
,
 $y$
,
 $t$
and parameter
 $\unicode[STIX]{x1D6FE}_{0}$
as follows. Let
 $$\begin{eqnarray}\displaystyle X=\unicode[STIX]{x1D6FF}^{1/2}x,\quad Y=\unicode[STIX]{x1D6FF}^{1/2}y,\quad T=\unicode[STIX]{x1D6FF}t,\quad \unicode[STIX]{x1D6FE}_{0}=\unicode[STIX]{x1D6E4}\unicode[STIX]{x1D6FF}, & & \displaystyle\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6FF}=\unicode[STIX]{x1D707}^{2}$
(and
 $\unicode[STIX]{x1D707}$
is the long-wave parameter defined in § 2),
 $\unicode[STIX]{x1D6FF}$
is assumed to be small (
 $\unicode[STIX]{x1D6FF}\ll 1$
) and
 $\unicode[STIX]{x1D6E4}=O(1)$
as
 $\unicode[STIX]{x1D6FF}\rightarrow 0$
.
In terms of the new variables, equations (3.42)–(3.46) become
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D713}_{z}^{2}}{2}-\unicode[STIX]{x1D718}\left[\frac{\hat{Q}^{2}}{2}-\hat{Q}\right]+\unicode[STIX]{x1D6FF}\left[\unicode[STIX]{x1D713}_{T}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}|^{2}}{2}+\unicode[STIX]{x1D6E4}\unicode[STIX]{x1D701}-\frac{\unicode[STIX]{x1D718}}{2}(1-\hat{Q})^{2}|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}|^{2}\right]=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6FF}[\unicode[STIX]{x1D701}_{T}+\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}]=\unicode[STIX]{x1D713}_{z}\quad \text{at }z=\unicode[STIX]{x1D701}(X,Y,T); & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D713}_{zz}+\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D713}=0\quad \text{for }-1<z<\unicode[STIX]{x1D701}(X,Y,T)\text{ and }\unicode[STIX]{x1D713}_{z}|_{z=-1}=0. & \displaystyle\end{eqnarray}$$
In (4.2)–(4.4),
 $\unicode[STIX]{x1D735}_{\shortparallel }=(\unicode[STIX]{x2202}_{X},\unicode[STIX]{x2202}_{Y})$
and
 $$\begin{eqnarray}\hat{Q}=\unicode[STIX]{x1D6F7}_{z}|_{z=\unicode[STIX]{x1D701}(X,Y,T)}\end{eqnarray}$$
and
 $\unicode[STIX]{x1D6F7}(X,Y,z,T)$
is the solution of the problem
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \unicode[STIX]{x1D6F7}_{zz}+\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D6F7}=0\quad \text{for }-1<z<\unicode[STIX]{x1D701}(X,Y,T),\\ \displaystyle \unicode[STIX]{x1D6F7}_{z}|_{z=-1}=0,\quad \unicode[STIX]{x1D6F7}|_{z=\unicode[STIX]{x1D701}(X,Y,T)}=\unicode[STIX]{x1D701}(X,Y,T).\end{array}\right\} & & \displaystyle\end{eqnarray}$$
Now we assume that
 $$\begin{eqnarray}\unicode[STIX]{x1D713}=\unicode[STIX]{x1D713}_{0}+\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}_{1}+\cdots \,,\quad \unicode[STIX]{x1D701}=\unicode[STIX]{x1D701}_{0}+\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}_{1}+\cdots \,,\quad \unicode[STIX]{x1D6F7}=\unicode[STIX]{x1D6F7}_{0}+\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D6F7}_{1}+\cdots \,,\text{etc.}\end{eqnarray}$$
On substituting these in (4.4) and collecting terms of the same order in
 $\unicode[STIX]{x1D6FF}$
, we obtain
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D713}_{0zz}=0,\quad \text{for }-1<z<\unicode[STIX]{x1D701}_{0}(X,Y,T)\text{ and }\unicode[STIX]{x1D713}_{0z}|_{z=-1}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D713}_{1zz}=-\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D713}_{0}\quad \text{for }-1<z<\unicode[STIX]{x1D701}_{0}(X,Y,T)\text{ and }\unicode[STIX]{x1D713}_{1z}|_{z=-1}=0. & \displaystyle\end{eqnarray}$$
From (4.8), we deduce that
 $\unicode[STIX]{x1D713}_{0}$
does not depend on
 $z$
:
 $$\begin{eqnarray}\unicode[STIX]{x1D713}_{0}=\unicode[STIX]{x1D713}_{0}(X,Y,T).\end{eqnarray}$$
In what follows, we only need
 $\unicode[STIX]{x1D713}_{1z}|_{z=\unicode[STIX]{x1D701}_{0}}$
. So, we integrate (4.9) in
 $z$
and apply the boundary condition at
 $z=-1$
. As a result, we get
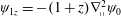 $\unicode[STIX]{x1D713}_{1z}=-(1+z)\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D713}_{0}$
, so that
 $$\begin{eqnarray}\unicode[STIX]{x1D713}_{1z}|_{z=\unicode[STIX]{x1D701}_{0}}=-(1+\unicode[STIX]{x1D701}_{0})\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D713}_{0}.\end{eqnarray}$$
Similarly, equation (4.6) yields
 $$\begin{eqnarray}\unicode[STIX]{x1D6F7}_{0}=\unicode[STIX]{x1D701}_{0}(X,Y,T)\quad \text{and}\quad \unicode[STIX]{x1D6F7}_{1z}|_{z=\unicode[STIX]{x1D701}_{0}}=-(1+\unicode[STIX]{x1D701}_{0})\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D701}_{0}.\end{eqnarray}$$
Hence,
 $$\begin{eqnarray}\hat{Q}_{0}=0\quad \text{and}\quad \hat{Q}_{1}=-(1+\unicode[STIX]{x1D701}_{0})\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D701}_{0}.\end{eqnarray}$$
Finally, we substitute (4.7) in (4.2) and (4.3) and employ (4.10)–(4.13). At leading order, we obtain
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D713}_{0T}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}|^{2}}{2}+\unicode[STIX]{x1D6E4}\unicode[STIX]{x1D701}_{0}-\unicode[STIX]{x1D718}\left[(1+\unicode[STIX]{x1D701}_{0})\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D701}_{0}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}_{0}|^{2}}{2}\right]=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D701}_{0T}+\unicode[STIX]{x1D735}_{\shortparallel }\boldsymbol{\cdot }[(1+\unicode[STIX]{x1D701}_{0})\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}_{0}]=0. & \displaystyle\end{eqnarray}$$
These are the shallow-water equations we were looking for. Note that if
 $\unicode[STIX]{x1D718}=0$
(i.e. there is no vibration), then these equations reduce to the standard shallow-water model.
Remark 3. As was mentioned at the beginning of this section, the long-wave model can also be derived directly from (2.4)–(2.7). This can be done using the same procedure as in § 3 under the following assumptions (cf. (3.1)):
 $$\begin{eqnarray}\unicode[STIX]{x1D707}=\unicode[STIX]{x1D716}^{1/2},\quad \unicode[STIX]{x1D6FC}=\unicode[STIX]{x1D716},\quad \unicode[STIX]{x1D6FD}=1,\quad \unicode[STIX]{x1D6FE}=\unicode[STIX]{x1D6E4}\unicode[STIX]{x1D716}^{2},\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6E4}$
is a constant of order 1 (i.e.
 $\unicode[STIX]{x1D6E4}=O(1)$
as
 $\unicode[STIX]{x1D716}\rightarrow 0$
). These assumptions mean that (i) the typical wavelength is much larger than the fluid depth, (ii) the amplitude of vibrations of the bottom is small compared with the fluid depth, (iii) the amplitude of the waves may be of the same order of magnitude as the fluid depth and (iv) the frequency of vibrations is high enough for the acceleration due to vibrations to be much higher than the gravitational acceleration.
Remark 4. For small-amplitude waves in the form
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D701}=\text{Re}(\hat{\unicode[STIX]{x1D701}}\text{e}^{\text{i}(\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}-\unicode[STIX]{x1D714}t)}),\quad \unicode[STIX]{x1D713}=\text{Re}(\hat{\unicode[STIX]{x1D713}}(z)\text{e}^{\text{i}(\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}-\unicode[STIX]{x1D714}t)}), & & \displaystyle\end{eqnarray}$$
where
 $\boldsymbol{k}=(k_{1},k_{2})$
, the dispersion relation has the form
 $$\begin{eqnarray}\unicode[STIX]{x1D714}^{2}(\boldsymbol{k})=|\boldsymbol{k}|^{2}(\unicode[STIX]{x1D6E4}+\unicode[STIX]{x1D718}|\boldsymbol{k}|^{2}).\end{eqnarray}$$
Note that (4.18) coincides with the standard dispersion relation for shallow-water gravity–capillary waves if
 $\unicode[STIX]{x1D718}$
is interpreted as surface tension (cf. Remark 2). Earlier, the fact that the effect of vibration is similar to that of surface tension was noticed by Lapuerta et al. (Reference Lapuerta, Mancebo and Vega2001) in the context of vibrational stabilisation of unstable two-fluid equilibria (with a layer of a heavier fluid on top of a lighter one).
4.2 Vibrations of finite amplitude
Now we drop our earlier assumption that the amplitude of vibrations is small (compared with the fluid depth). Namely, we assume that (cf. (4.2))
 $$\begin{eqnarray}\unicode[STIX]{x1D707}=\unicode[STIX]{x1D716}^{1/2},\quad \unicode[STIX]{x1D6FC}=1,\quad \unicode[STIX]{x1D6FD}=1,\quad \unicode[STIX]{x1D6FE}=\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D716},\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6FE}_{0}=O(1)$
as
 $\unicode[STIX]{x1D716}\rightarrow 0$
. In other words, our assumptions are: (i) the typical wavelength is much larger that the fluid depth, (ii) the amplitude of vibrations is of the same order of magnitude as the fluid depth, (iii) the amplitude of the waves is of the same order of magnitude as the fluid depth and (iv) the frequency of vibrations is high enough for the acceleration due to vibrations to be much higher than the gravitational acceleration (but not as high as in § 4.1, cf. (4.16)). Note that the model discussed below cannot be derived from the general model of § 3, because the latter works only for small-amplitude vibrations. So, we need to start with (2.4)–(2.7).
Substituting (4.19) into (2.4)–(2.7), we obtain
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{zz}+\unicode[STIX]{x1D716}\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D719}=0\quad \text{for }-1<z<\unicode[STIX]{x1D702}(x,y,\unicode[STIX]{x1D70F}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{\unicode[STIX]{x1D70F}}+f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}+\frac{\unicode[STIX]{x1D719}_{z}^{2}}{2}+\unicode[STIX]{x1D716}\left(\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D702}\right)=0\quad \text{at }z=\unicode[STIX]{x1D702}(x,y,\unicode[STIX]{x1D70F}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{z}=0\quad \text{at }z=-1, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}_{\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D716}\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D702}=\unicode[STIX]{x1D719}_{z}\quad \text{at }z=\unicode[STIX]{x1D702}(x,y,\unicode[STIX]{x1D70F}). & \displaystyle\end{eqnarray}$$
The asymptotic expansion for
 $\unicode[STIX]{x1D716}\ll 1$
is constructed in appendix A using the same procedure as in § 3. Here we only describe the results. The expansion has the form
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}=\unicode[STIX]{x1D713}(x,y,t)+\tilde{\unicode[STIX]{x1D719}}_{0}(x,y,\unicode[STIX]{x1D70F},t)+O(\unicode[STIX]{x1D716}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}=\unicode[STIX]{x1D701}(x,y,t)+O(\unicode[STIX]{x1D716}), & \displaystyle\end{eqnarray}$$
where
 $\tilde{\unicode[STIX]{x1D719}}_{0}=-f^{\prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D701}$
and functions
 $\unicode[STIX]{x1D713}$
and
 $\unicode[STIX]{x1D701}$
satisfy the following closed system of evolution equations:
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D713}_{t}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D701}-\unicode[STIX]{x1D718}\left[(1+\unicode[STIX]{x1D701})\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D701}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}|^{2}}{2}\right]=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D701}_{t}+\unicode[STIX]{x1D735}_{\shortparallel }\boldsymbol{\cdot }[(1+\unicode[STIX]{x1D701})\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}]=0. & \displaystyle\end{eqnarray}$$
In (4.24)–(4.27),
 $\unicode[STIX]{x1D718}$
is the vibrational parameter, defined by (3.38), and
 $$\begin{eqnarray}\displaystyle t=\unicode[STIX]{x1D716}\unicode[STIX]{x1D70F} & & \displaystyle\end{eqnarray}$$
is the slow time. Note that this slow time is different from the slow time employed in § 4.1, but the same as the slow time of § 3.
Evidently, if we replace
 $\unicode[STIX]{x1D6FE}_{0}$
in (4.26) with
 $\unicode[STIX]{x1D6E4}$
(defined by (4.16)), then (4.26) and (4.27) become exactly the same as (4.14) and (4.15). It is quite remarkable that the same asymptotic equations describe two physically different situations (small-amplitude vibrations and vibrations of finite amplitude).
Remark 5. The two long-wave asymptotic models derived in this section correspond to physically different situations, yet the asymptotic equations are the same. This fact looks surprising, but it is not coincidental. It turns out that the same asymptotic equations arise in many (physically) different situations, namely, under the following conditions:
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D707}^{2}\ll 1,\quad \unicode[STIX]{x1D6FC}\unicode[STIX]{x1D707}^{2}\ll 1,\quad \unicode[STIX]{x1D6FE}=\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D6FC}\unicode[STIX]{x1D707}^{2}. & & \displaystyle\end{eqnarray}$$
More precisely, it can be shown that if
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D707}^{2}=\unicode[STIX]{x1D716}^{n},\quad \unicode[STIX]{x1D6FC}=\unicode[STIX]{x1D716}^{m},\quad \unicode[STIX]{x1D6FE}=\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D716}^{n+m} & & \displaystyle\end{eqnarray}$$
for any integers
 $n$
and
 $m$
such that
 $n>0$
and
 $m>-n$
and
 $\unicode[STIX]{x1D6FD}=O(1)$
,
 $\unicode[STIX]{x1D6FE}_{0}=O(1)$
as
 $\unicode[STIX]{x1D716}\rightarrow 0$
, then the asymptotic procedure of the present paper yields, at leading order, equations (4.26) and (4.27) with slow time
 $t=\unicode[STIX]{x1D716}^{n+m}\unicode[STIX]{x1D70F}$
. This implies that
 $\unicode[STIX]{x1D6FC}$
can be large, provided that
 $\unicode[STIX]{x1D707}$
is sufficiently small. Physically this means that the amplitude of the vibration can be much greater than the fluid depth, if the waves considered are sufficiently long. For example, if we let
 $\unicode[STIX]{x1D707}^{2}=\unicode[STIX]{x1D716}^{2}$
,
 $\unicode[STIX]{x1D6FC}=\unicode[STIX]{x1D716}^{-1}$
and
 $\unicode[STIX]{x1D6FE}=\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D716}$
, then all the above conditions are satisfied. It should be mentioned that the vibration with the amplitude much greater than the fluid depth is very difficult, if not impossible, to realise experimentally. Also, vibrations of high frequency and large amplitude may lead to cavitation, which is not covered by the present theory. These, as well as the fact that calculations become much more lengthy in the general case, are the reasons why we restricted our attention to the cases of small and finite vibration amplitudes.
Remark 6. Equations (4.26) and (4.27) conserve the energy, given by
 $$\begin{eqnarray}H=\int \left((1+\unicode[STIX]{x1D701})\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D713}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\frac{\unicode[STIX]{x1D701}^{2}}{2}+\unicode[STIX]{x1D718}(1+\unicode[STIX]{x1D701})\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}|^{2}}{2}\right)\text{d}x\,\text{d}y.\end{eqnarray}$$
It is easy to verify that (4.26) and (4.27) are Hamiltonian:
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D701}_{t}=\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D713}},\quad \unicode[STIX]{x1D713}_{t}=-\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}. & & \displaystyle\end{eqnarray}$$
Note also that the above Hamiltonian,
 $H$
, can be obtained from (3.47) just by assuming that
 $\unicode[STIX]{x1D713}$
and
 $\unicode[STIX]{x1D6F7}$
in (3.47) do not depend on the vertical coordinate
 $z$
(which corresponds to the long-wave approximation) and then integrating in
 $z$
.
5 One-dimensional waves
The aim of this section is to demonstrate that the averaged equations (4.26) and (4.27) have both solitary and periodic travelling wave solutions. Here we consider one-dimensional waves and assume that
 $\unicode[STIX]{x1D713}$
and
 $\unicode[STIX]{x1D701}$
do not depend on
 $y$
. It is convenient to rewrite the one-dimensional version of (4.26) and (4.27) in terms of the velocity,
 $u$
, and the total depth of the fluid,
 $h$
, defined by
 $$\begin{eqnarray}\displaystyle u(x,t)=\unicode[STIX]{x1D713}_{x}(x,t),\quad h(x,t)=1+\unicode[STIX]{x1D701}(x,t). & & \displaystyle\end{eqnarray}$$
In terms of
 $u$
and
 $h$
, we have
 $$\begin{eqnarray}\displaystyle & \displaystyle u_{t}+\left(\frac{u^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}h-\unicode[STIX]{x1D718}\left[hh_{xx}+\frac{h_{x}^{2}}{2}\right]\right)_{x}=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle h_{t}+(hu)_{x}=0. & \displaystyle\end{eqnarray}$$
Equation (5.3) represents the conservation law of mass. Equation (5.2) is associated with conservation of momentum: with the help of (5.3) it can be rewritten as
 $$\begin{eqnarray}(hu)_{t}+\left(hu^{2}+\unicode[STIX]{x1D6FE}_{0}\frac{h^{2}}{2}-\unicode[STIX]{x1D718}h^{2}h_{xx}\right)_{x}=0,\end{eqnarray}$$
which is precisely the momentum conservation law. Equations (5.2) and (5.3) also imply the conservation law of energy:
 $$\begin{eqnarray}{\mathcal{E}}_{t}+{\mathcal{W}}_{x}=0,\end{eqnarray}$$
where
 $$\begin{eqnarray}\displaystyle & \displaystyle {\mathcal{E}}=h\frac{u^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\frac{h^{2}}{2}+\unicode[STIX]{x1D718}h\frac{h_{x}^{2}}{2}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle {\mathcal{W}}=hu\frac{u^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}uh^{2}-\unicode[STIX]{x1D718}hu\left(hh_{xx}-\frac{h_{x}^{2}}{2}\right)+\unicode[STIX]{x1D718}h^{2}h_{x}u_{x}. & \displaystyle\end{eqnarray}$$
Our conjecture is that there are no other conserved quantities, depending on
 $u$
,
 $h$
and
 $h_{x}$
only, but we did not attempt to prove this.
Now let us show that (5.2) and (5.3) have travelling wave solutions. We look for solutions of these equations in the form
 $$\begin{eqnarray}\displaystyle u(x,t)=U(s),\quad h(x,t)=H(s),\quad s\equiv x-ct, & & \displaystyle\end{eqnarray}$$
where
 $c$
is a real parameter (its positive and negative values corresponds to waves travelling to the right and to the left, respectively). Substituting these into (5.2) and (5.3) and integrating once in
 $s$
, we arrive at the following equations:
 $$\begin{eqnarray}\displaystyle & \displaystyle -cU+\frac{U^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}H-\unicode[STIX]{x1D718}\left[HH^{\prime \prime }+\frac{{H^{\prime }}^{2}}{2}\right]=C, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle -cH+HU=B, & \displaystyle\end{eqnarray}$$
where
 $C$
and
 $B$
are constants of integration. It follows from (5.10) that
 $$\begin{eqnarray}U=\frac{B}{H}+c,\end{eqnarray}$$
and we use this to eliminate
 $U$
from (5.9). As a result, equation (5.9) can be written as
 $$\begin{eqnarray}m\left(HH^{\prime \prime }+\frac{{H^{\prime }}^{2}}{2}\right)=\frac{\hat{B}^{2}}{2H^{2}}+H-{\hat{C}},\end{eqnarray}$$
where
 $$\begin{eqnarray}m=\frac{\unicode[STIX]{x1D718}}{\unicode[STIX]{x1D6FE}_{0}},\quad \hat{B}=\frac{B}{\sqrt{\unicode[STIX]{x1D6FE}_{0}}},\quad {\hat{C}}=\frac{C}{\unicode[STIX]{x1D6FE}_{0}}+\frac{{\hat{c}}^{2}}{2},\quad {\hat{c}}=\frac{c}{\sqrt{\unicode[STIX]{x1D6FE}_{0}}}.\end{eqnarray}$$
Equation (5.12) is valid for any
 $\unicode[STIX]{x1D718}\geqslant 0$
and
 $\unicode[STIX]{x1D6FE}_{0}>0$
and contains three free parameters (
 $m$
,
 $\hat{B}$
and
 ${\hat{C}}$
). The case of
 $\unicode[STIX]{x1D6FE}_{0}=0$
(when the vibrations dominate over the gravity in the averaged dynamics) will be treated separately. To reduce the number of parameters and transform (5.12) to a more convenient form, we introduce the following new dependent and independent variables:
 $$\begin{eqnarray}H(s)=\frac{{\hat{C}}}{3}R^{2/3}(\unicode[STIX]{x1D70E}),\quad \unicode[STIX]{x1D70E}=m^{-1/2}\left(\frac{{\hat{C}}}{3}\right)^{-1/2}s.\end{eqnarray}$$
We are interested in solutions of (5.12) that are positive and bounded (
 $0<H(s)<\infty$
). For such solutions,
 $R(\unicode[STIX]{x1D70E})$
is well-defined, positive and bounded. Equation (5.12) can be rewritten in term of
 $R$
and
 $\unicode[STIX]{x1D70E}$
as
 $$\begin{eqnarray}R^{\prime \prime }(\unicode[STIX]{x1D70E})=-\hat{V}^{\prime }(R),\end{eqnarray}$$
where
 $$\begin{eqnarray}\hat{V}(R)={\textstyle \frac{9}{8}}(4qR^{-2/3}-R^{4/3}+6R^{2/3})\end{eqnarray}$$
and
 $$\begin{eqnarray}q=\frac{\hat{B}^{2}}{4}\left(\frac{{\hat{C}}}{3}\right)^{-3}.\end{eqnarray}$$
Evidently, equation (5.15) coincides with the equation of motion of a particle of unit mass moving in the potential
 $\hat{V}(R)$
, with
 $\unicode[STIX]{x1D70E}$
playing the role of time. Now it is easy to show the existence of travelling periodic and solitary wave solutions of (5.2) and (5.3): all we need to do is to find bounded periodic and non-periodic solutions of (5.15). Note that, since only the square of
 ${\hat{c}}$
appears in (5.12), there are waves of the same shape travelling to the left and to the right, and it is sufficient to consider only positive
 ${\hat{c}}$
.
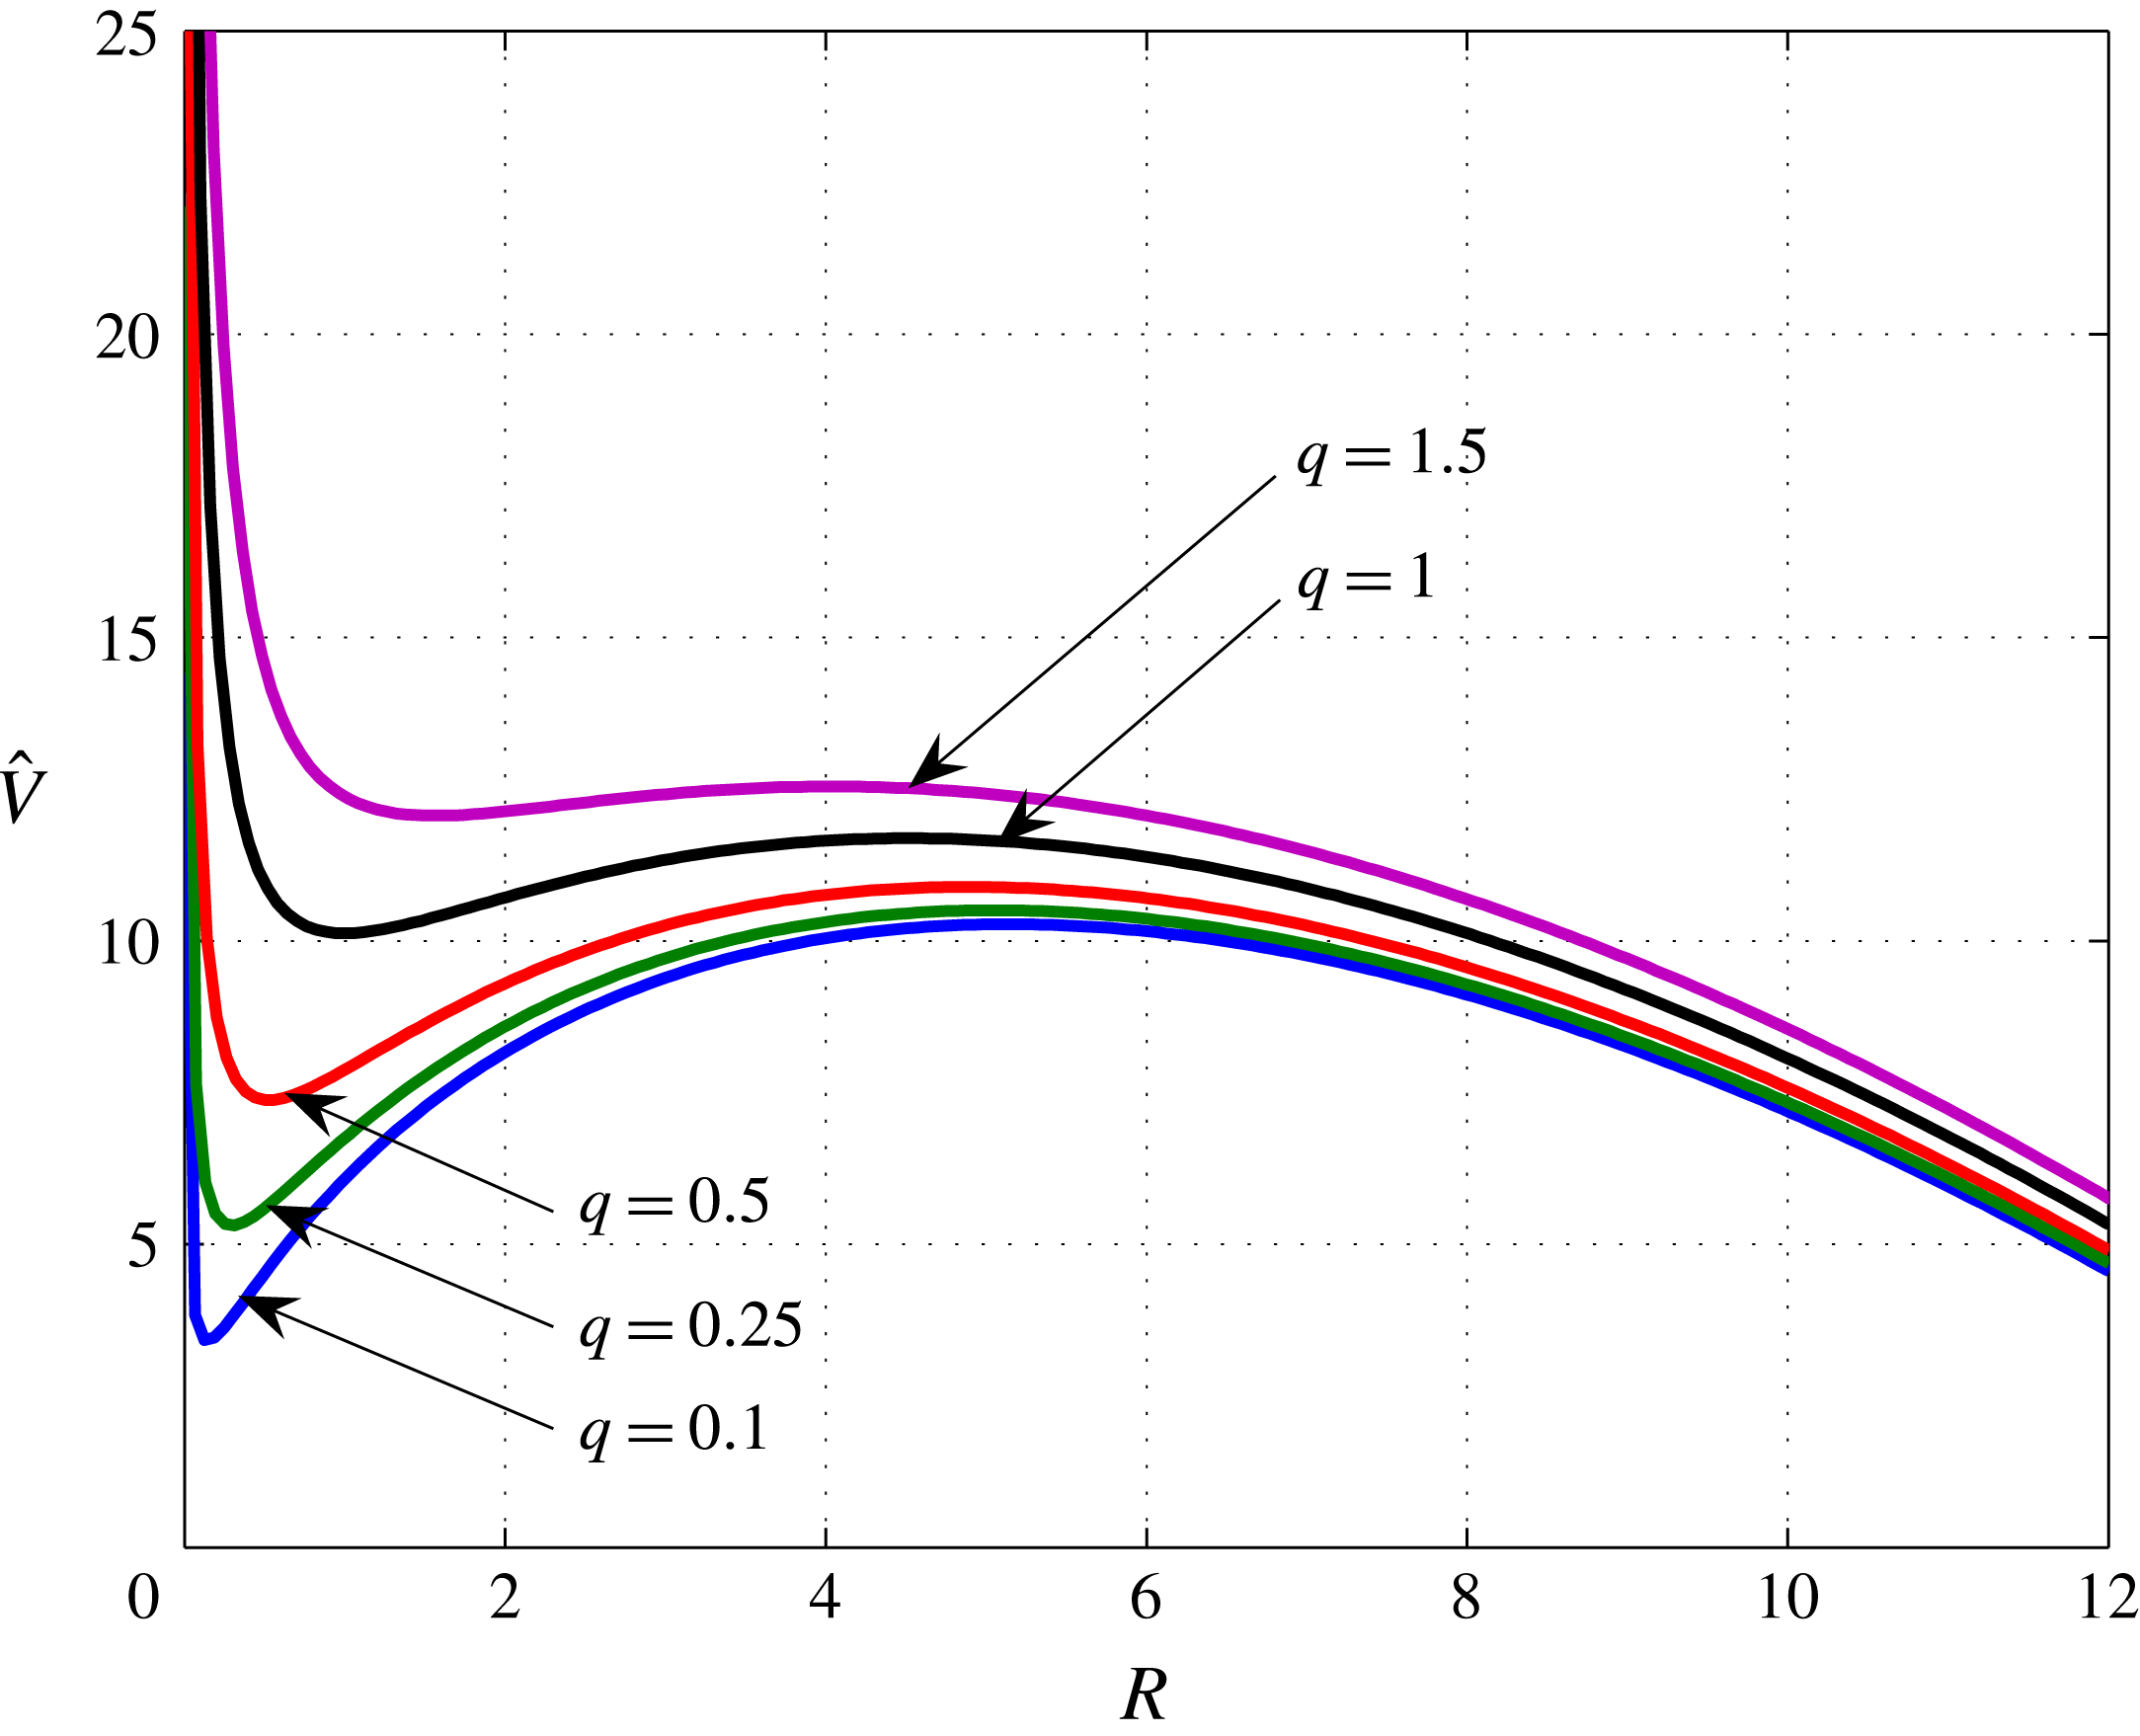
The potential
 $\hat{V}(R)$
contains only one free parameter,
 $q$
. Its graphs for several values of
 $q$
are shown in figure 2. For
 $0<q<2$
, function
 $\hat{V}(R)$
has a local minimum at
 $R=R_{1}$
and a local maximum at
 $R=R_{2}$
where
 $$\begin{eqnarray}R_{1}=[1-2\cos (\unicode[STIX]{x1D6FC}/3+\unicode[STIX]{x03C0}/3)]^{3/2},\quad R_{2}=[1+2\cos (\unicode[STIX]{x1D6FC}/3)]^{3/2},\quad \cos \unicode[STIX]{x1D6FC}=1-q.\end{eqnarray}$$
For
 $q<0$
or
 $q>2$
, there are no local maximum and minimum, and, therefore, no solutions satisfying
 $0<R(\unicode[STIX]{x1D70E})<\infty$
for all
 $\unicode[STIX]{x1D70E}\in \mathbb{R}$
exist.
Plots of
 $\hat{V}(R)$
for several values of parameter
 $q$
(
 $0<q<2$
).

Below we separately consider solitary waves, periodic waves and the case of
 $\unicode[STIX]{x1D6FE}_{0}=0$
.
5.1 Solitary waves
Solitary travelling waves correspond to finite, but non-periodic motions of the particle. In view of figure 2, these requirements are satisfied if the particle’s energy,
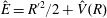 $\hat{E}={R^{\prime }}^{2}/2+\hat{V}(R)$
, is equal to the value of
 $\hat{V}$
at the local maximum, i.e.
 $\hat{E}=\hat{V}(R_{2})$
. Thus, for each value of parameter
 $q\in (0,2)$
, we obtain a solitary wave solution of (5.2) and (5.3). In what follows, we restrict our attention to solitary waves satisfying the conditions
 $$\begin{eqnarray}\displaystyle u(x,t)\rightarrow 0,\quad h(x,t)\rightarrow 1\quad \text{as }|x|\rightarrow \infty , & & \displaystyle\end{eqnarray}$$
which, in terms of
 $H(s)$
and
 $U(s)$
, have the form
 $$\begin{eqnarray}U(s)\rightarrow 0,\quad H(s)\rightarrow 1\quad \text{as }|s|\rightarrow \infty .\end{eqnarray}$$
When
 $\unicode[STIX]{x1D70E}\rightarrow \pm \infty$
, the particle approaches the point
 $R=R_{2}$
. This fact and (5.20a,b
) imply that
 $$\begin{eqnarray}\frac{{\hat{C}}}{3}\left(1+2\cos \frac{\unicode[STIX]{x1D6FC}}{3}\right)=1.\end{eqnarray}$$
It also follows from conditions (5.20a,b ) and (5.9) and (5.10) that
 $$\begin{eqnarray}B=-c,\quad C=\unicode[STIX]{x1D6FE}_{0},\quad \hat{B}=-{\hat{c}},\quad {\hat{C}}=1+\frac{{\hat{c}}^{2}}{2}.\end{eqnarray}$$
These and (5.17) give us the following relationship between parameter
 $q$
and the wave speed
 ${\hat{c}}$
:
 $$\begin{eqnarray}q=\frac{27}{4}{\hat{c}}^{2}\left(1+\frac{{\hat{c}}^{2}}{2}\right)^{-3}.\end{eqnarray}$$
Note that (5.21) and (5.23) are not independent: if (5.23) holds, so does (5.21), or vice versa. The requirement that
 $0<q<2$
and (5.23) imply that
 $0<{\hat{c}}<1$
, which means solitary wave can propagate only with speed less than the phase speed of small-amplitude gravity waves,
 $\sqrt{\unicode[STIX]{x1D6FE}_{0}}$
.
Equation (5.15) was solved numerically for various values of
 $q$
using the MATLAB built-in ordinary differential equation (ODE) solvers. Then, equation (5.14) was employed to compute
 $H(s)$
and the wave amplitude,
 $A$
, defined as
 $$\begin{eqnarray}A=\max _{s\in \mathbb{R}}|H(s)-1|.\end{eqnarray}$$
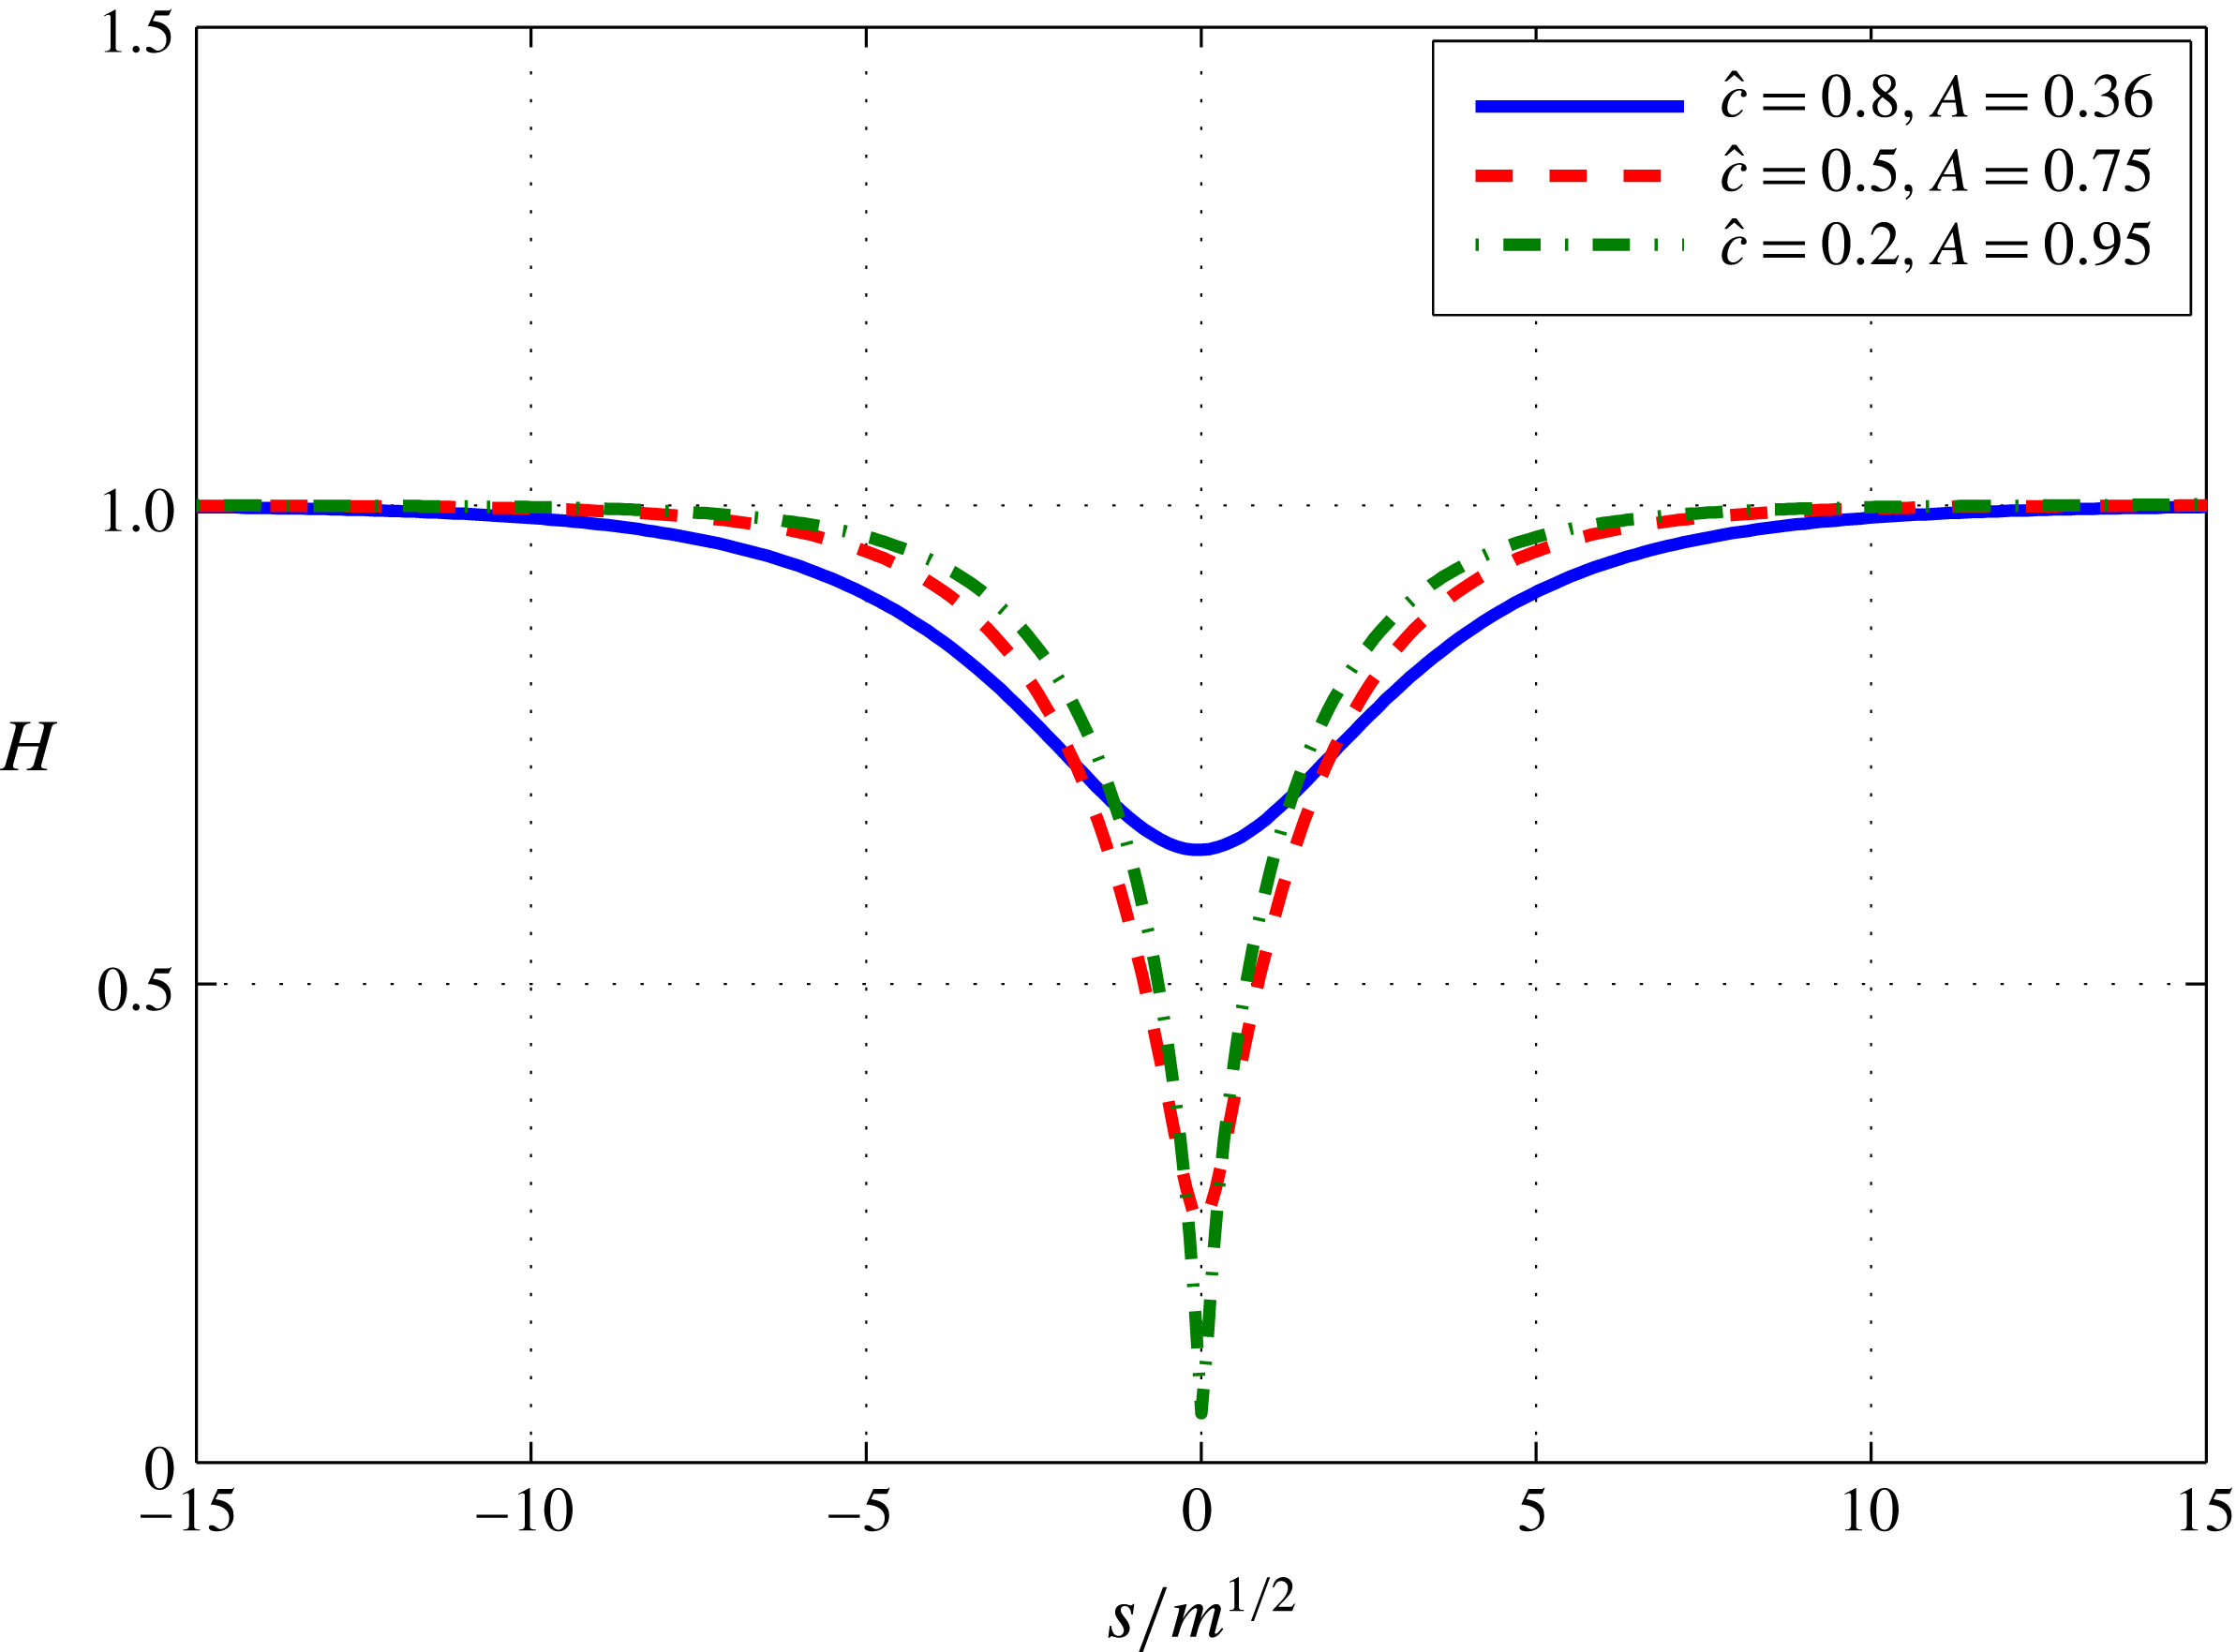
Typical shapes of the solitary waves are presented in figure 3. Figure 3 shows that the only type of possible solitary waves are depression waves. It is known that the depression capillary–gravity solitary waves are possible (see Korteweg & de Vries Reference Korteweg and de Vries1895; Benjamin Reference Benjamin1982; Vanden-Broeck & Shen Reference Vanden-Broeck and Shen1983) and have been observed experimentally in fluids with sufficiently strong surface tension (Falcon, Laroche & Fauve Reference Falcon, Laroche and Fauve2002). This gives us one more argument in favour of our earlier conclusion that the effect of vibrations is similar to that of surface tension.
The wave speed,
 ${\hat{c}}=c/\sqrt{\unicode[STIX]{x1D6FE}_{0}}$
, versus the amplitude,
 $A$
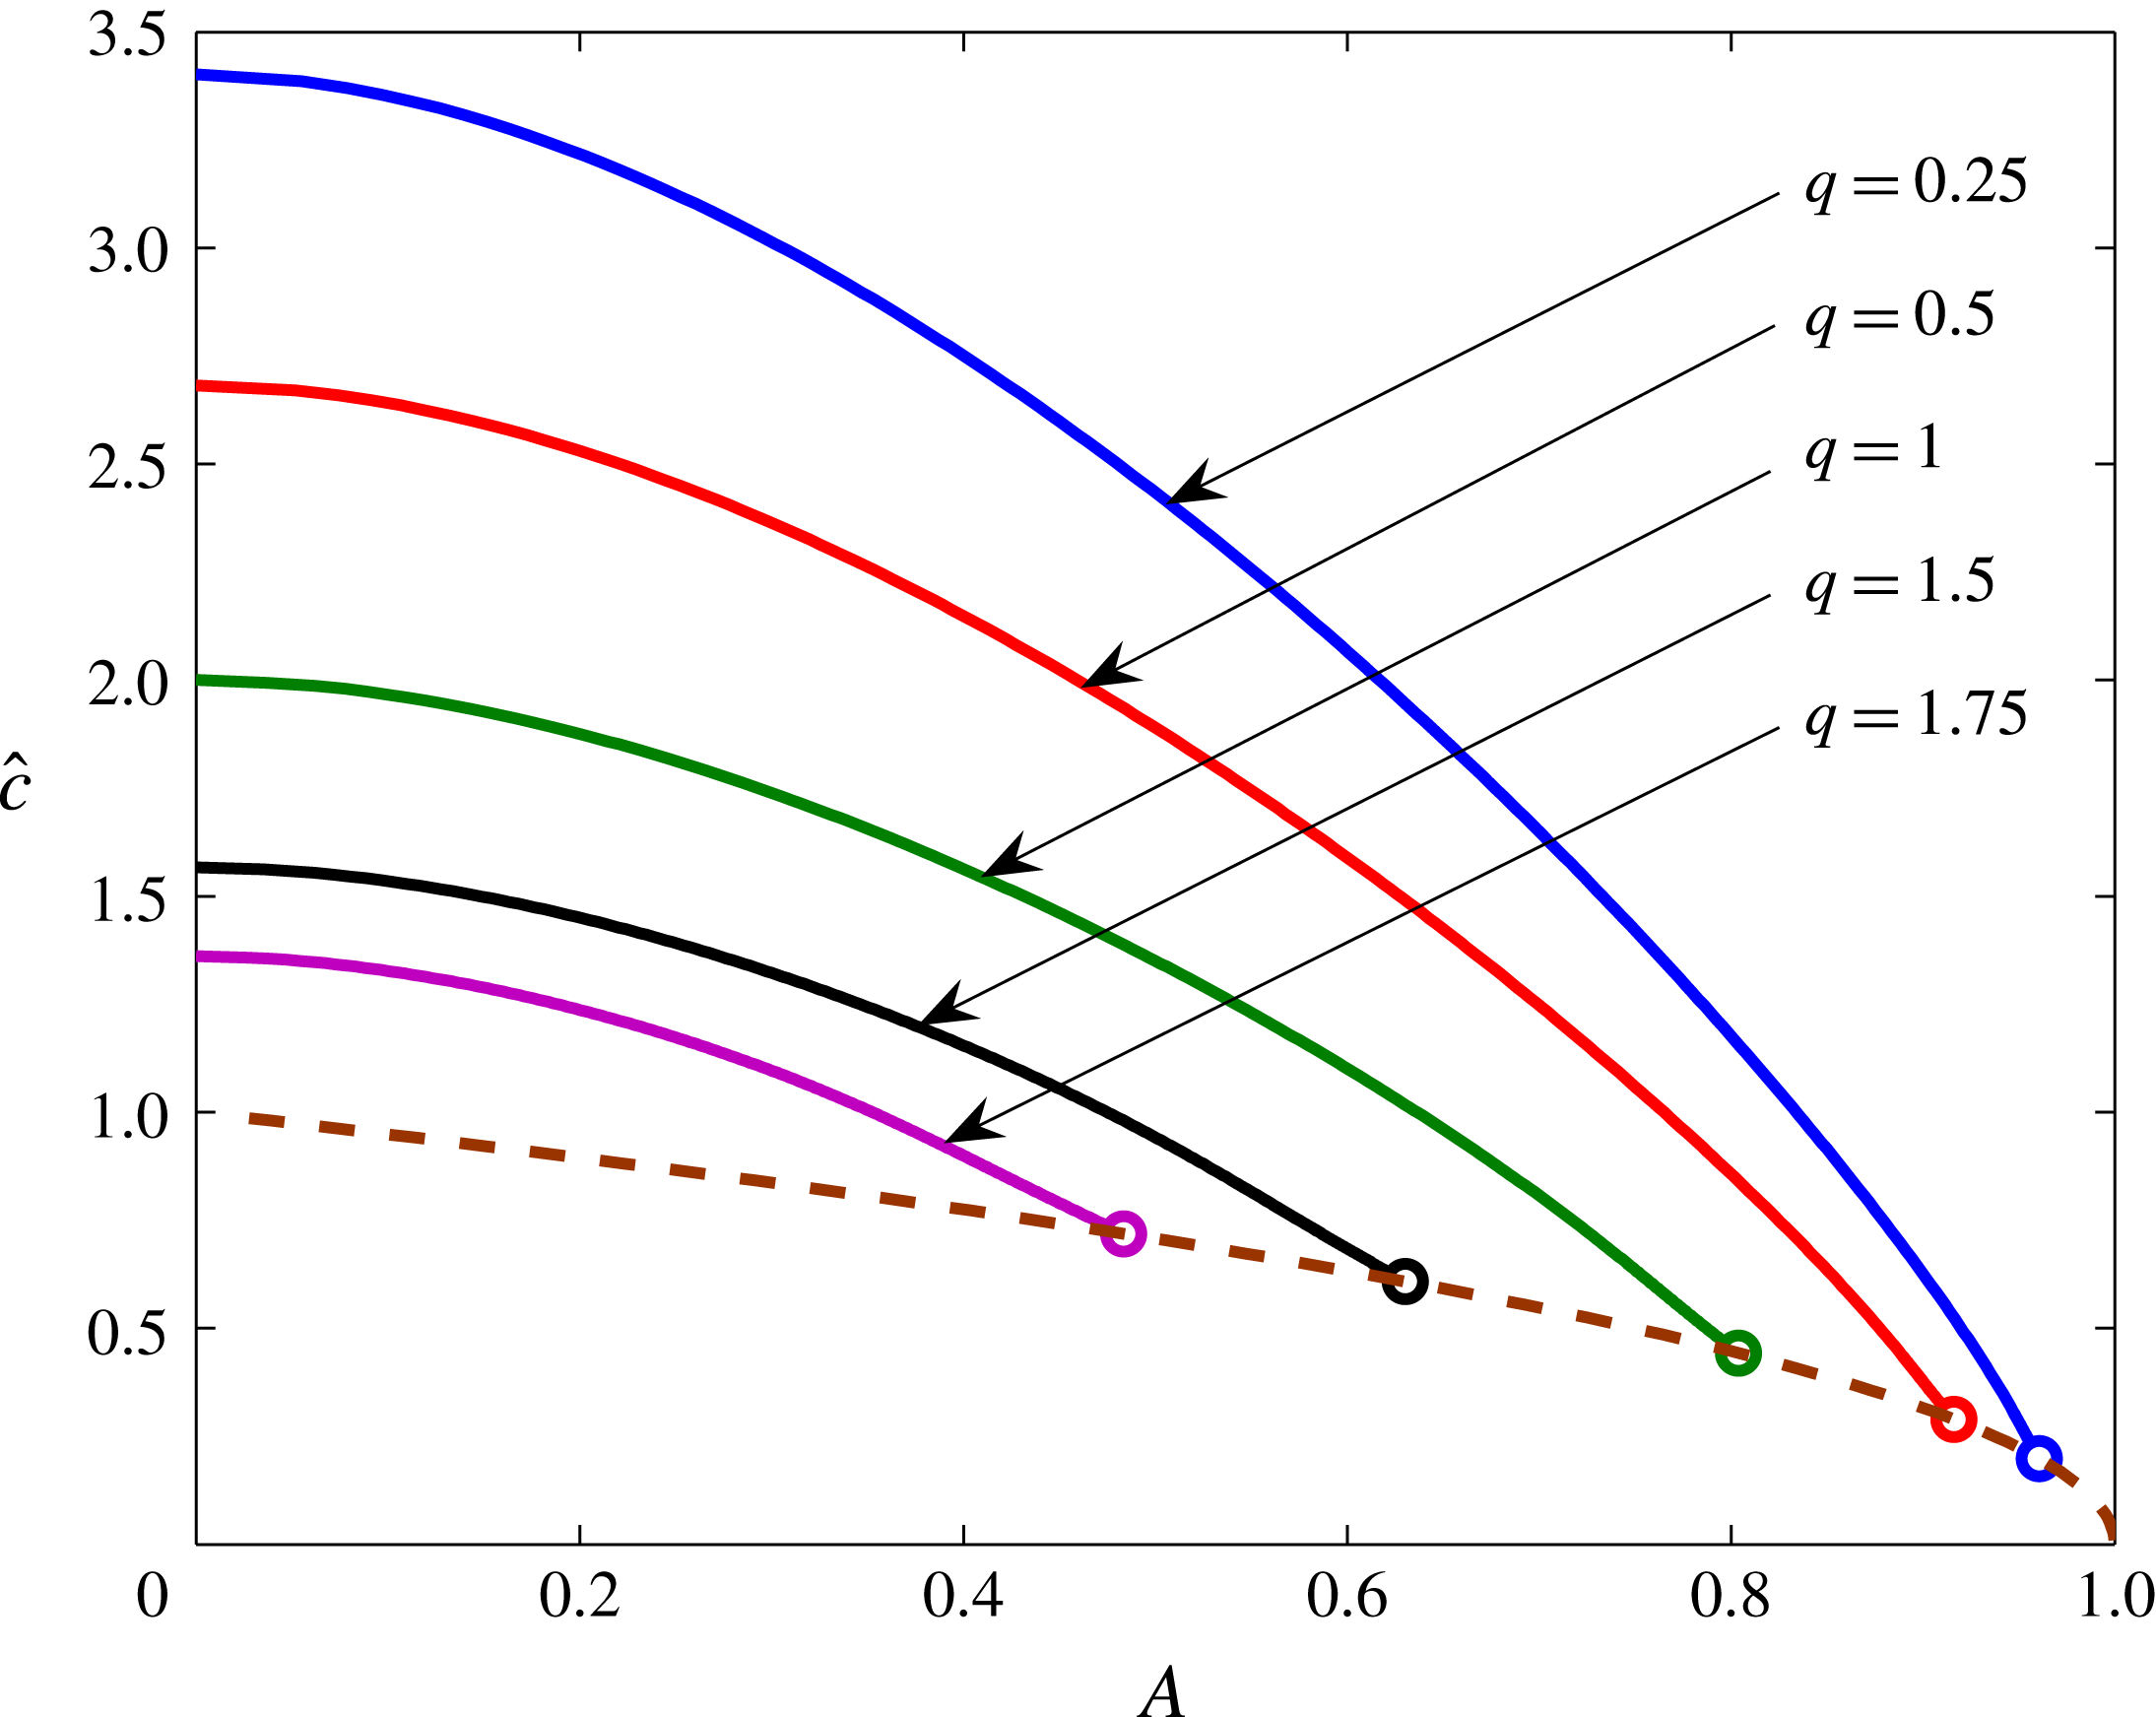
, is shown in figure 4 as a dashed curve. It approaches
 $1$
when the amplitude decreases to zero and
 $0$
when the amplitude approaches
 $1$
. The solid curves in figure 4 correspond to periodic travelling waves discussed below.
Typical profiles of solitary waves.

Wave speed
 ${\hat{c}}=c/\sqrt{\unicode[STIX]{x1D6FE}_{0}}$
versus amplitude
 $A$
. Solid curves show the wave speed of periodic waves for several values of parameter
 $q$
. The dashed curve corresponds to solitary waves. Circles represent the limit points of the wave speed of periodic waves when the wavelength goes to infinity.

5.2 Periodic waves
It follows from figure 2 that the motion of the particle is periodic if the particle’s energy,
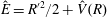 $\hat{E}={R^{\prime }}^{2}/2+\hat{V}(R)$
, satisfies the inequality
 $$\begin{eqnarray}\hat{V}(R_{1})<\hat{E}<\hat{V}(R_{2}).\end{eqnarray}$$
Periodic motions of the particle correspond to periodic travelling waves solutions of the original equations (5.2) and (5.3). For each
 $q\in (0,2)$
, there is a family of periodic solutions corresponding to values of the particle’s energy,
 $\hat{E}$
, satisfying inequality (5.25). In what follows, we restrict our attention to waves for which the mass flux (equivalently, the momentum density),
 $M=HU$
, averaged over the period of the wave, is zero, i.e.
 $$\begin{eqnarray}\langle M\rangle \equiv \frac{1}{S}\int _{0}^{S}H(s)U(s)\,\text{d}s=0.\end{eqnarray}$$
Here
 $S$
is the period (wavelength) of the wave. Also, to be consistent with our non-dimensionalisation, we require that the averaged (over the period) fluid depth is equal to
 $1$
, i.e.
 $$\begin{eqnarray}\langle H\rangle \equiv \frac{1}{S}\int _{0}^{S}H(s)\,\text{d}s=1.\end{eqnarray}$$
On averaging (5.10) over the period and taking into account (5.26) and (5.27), we find the relationship between
 $B$
and
 $c$
:
 $$\begin{eqnarray}B=-c\quad \text{or}\quad \hat{B}=-{\hat{c}}.\end{eqnarray}$$
Since the particle’s energy is a constant of motion (
 $\text{d}\hat{E}/\text{d}s=0$
), we have
 $$\begin{eqnarray}R^{\prime }(s)=\pm \sqrt{2(\hat{E}-\hat{V}(R))}.\end{eqnarray}$$
Hence, the period of motion of the particle is given by
 $$\begin{eqnarray}\unicode[STIX]{x1D6F4}=2\int _{R_{min}}^{R_{max}}\frac{\text{d}R}{\sqrt{2(\hat{E}-\hat{V}(R))}},\end{eqnarray}$$
where
 $R_{max}$
and
 $R_{min}$
are the maximum and minimum values of
 $R$
corresponding to periodic motion of the particle with energy
 $\hat{E}$
(in other words,
 $R_{max}$
and
 $R_{min}$
are solutions of the equation
 $\hat{V}(R)=\hat{E}$
). In view of (5.14), the period of function
 $H(s)$
(the wavelength) is then given by
 $$\begin{eqnarray}S=m^{1/2}\left(\frac{{\hat{C}}}{3}\right)^{1/2}\unicode[STIX]{x1D6F4}.\end{eqnarray}$$
Further, on rewriting the integral in (5.27) in terms of
 $R$
and
 $\unicode[STIX]{x1D70E}$
, we obtain
 $$\begin{eqnarray}\left(\frac{{\hat{C}}}{3}\right)^{-1}=\frac{1}{\unicode[STIX]{x1D6F4}}\int _{0}^{\unicode[STIX]{x1D6F4}}R^{2/3}(\unicode[STIX]{x1D70E})\,\text{d}\unicode[STIX]{x1D70E}=\frac{2}{\unicode[STIX]{x1D6F4}}\int _{R_{min}}^{R_{max}}\frac{R^{2/3}\,\text{d}R}{\sqrt{2(\hat{E}-\hat{V}(R))}}.\end{eqnarray}$$
Now all properties of the periodic solutions can be found as follows. First, we fix
 $q\in (0,2)$
. Then for each
 $\hat{E}$
satisfying (5.25), we compute
 ${\hat{C}}$
,
 $S$
(using (5.32) and (5.31), respectively) and
 ${\hat{c}}$
(using (5.17) and (5.28)), as well as the wave amplitude,
 $A$
, defined by
 $$\begin{eqnarray}A=\max _{s\in [0,S]}|H(s)-1|=\frac{{\hat{C}}}{3}\max \{1-R_{min}^{2/3},R_{max}^{2/3}-1\}.\end{eqnarray}$$
As a result, we get the period,
 $S$
, and the wave speed,
 ${\hat{c}}$
, as functions of the amplitude,
 $A$
.
Period
 $S$
versus amplitude
 $A$
for several values of parameter
 $q$
. Dashed vertical lines represent the asymptotes of the curves
 $S(A)$
. These asymptotes correspond to solitary waves.

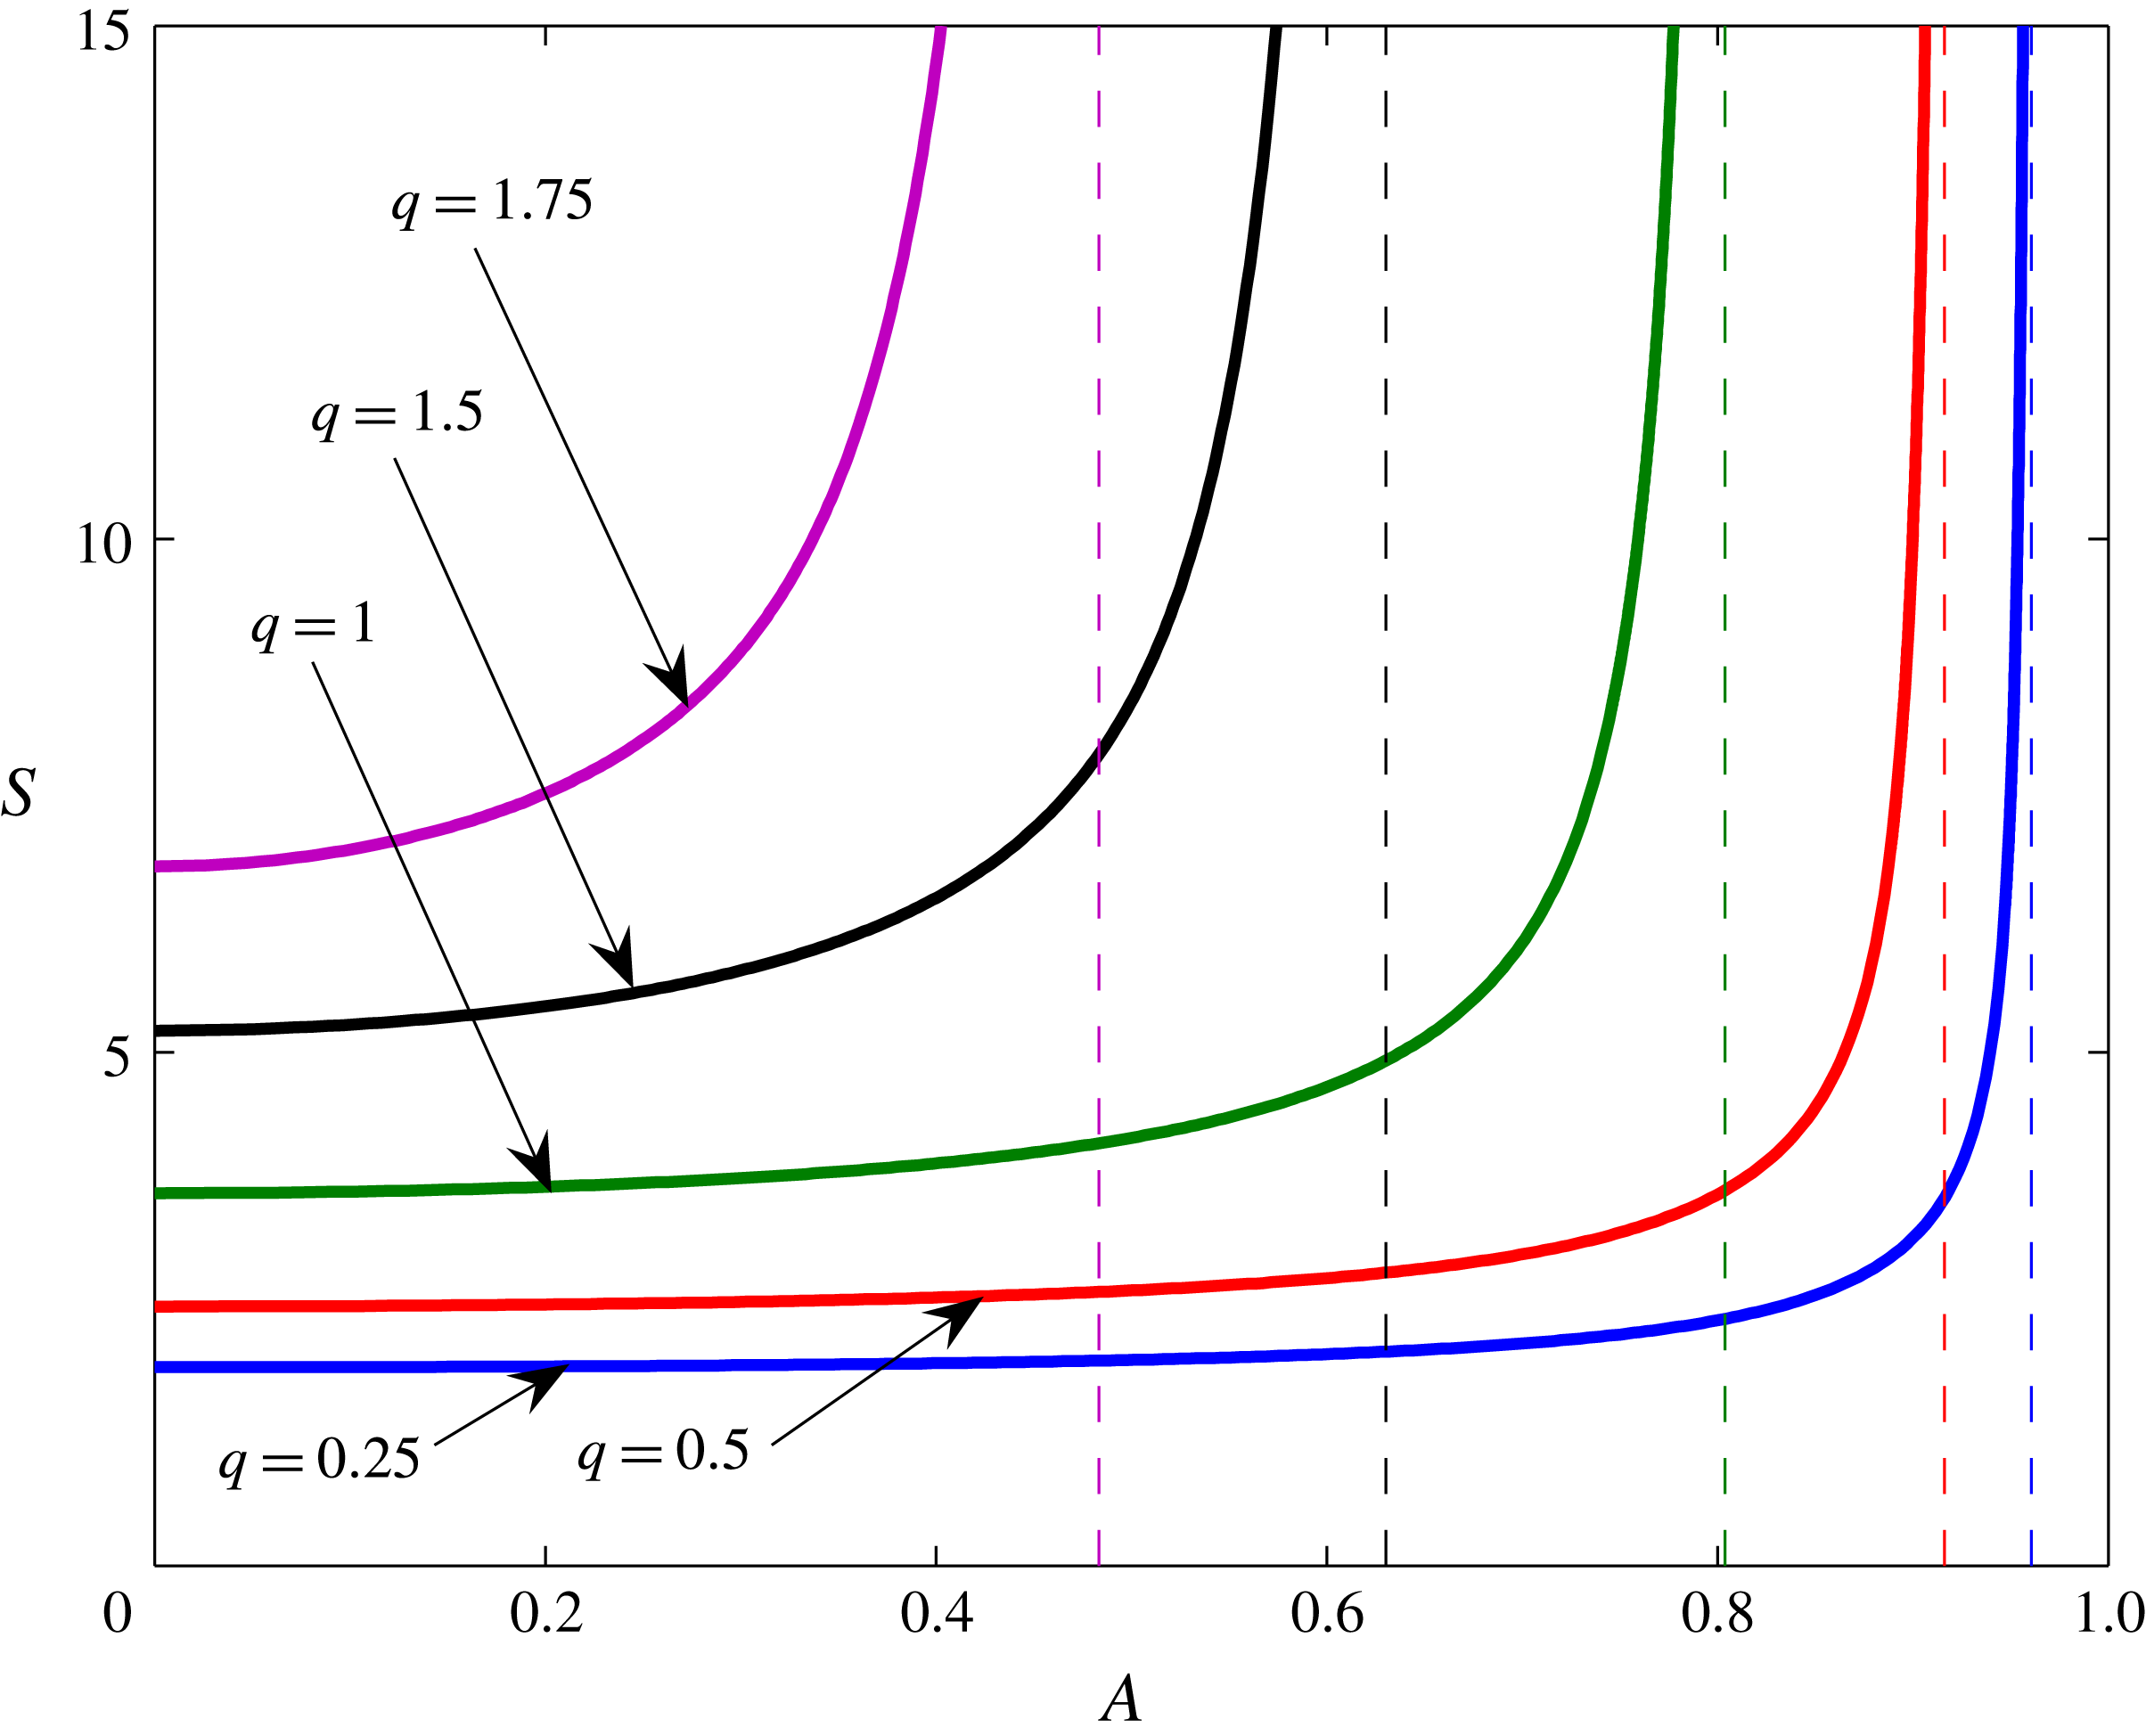
The period versus the amplitude for several values of parameter
 $q$
are shown in figure 5. The figure shows that for each value of
 $q$
,
 $S(A)$
increases with
 $A$
and goes to infinity as
 $A$
approaches a certain critical value, which corresponds to the amplitude of the solitary wave for the same value of
 $q$
. The dashed vertical asymptotes of the curves
 $S(A)$
, shown in figure 5, represent the amplitudes of the corresponding solitary waves. The wave speed as a function of the amplitude for several values of
 $q$
is shown in figure 4: solid curves. For each
 $q$
,
 ${\hat{c}}$
decreases as
 $A$
varies from
 $0$
up to the critical amplitude (corresponding to a solitary wave). The end points of the curves,
 ${\hat{c}}(A)$
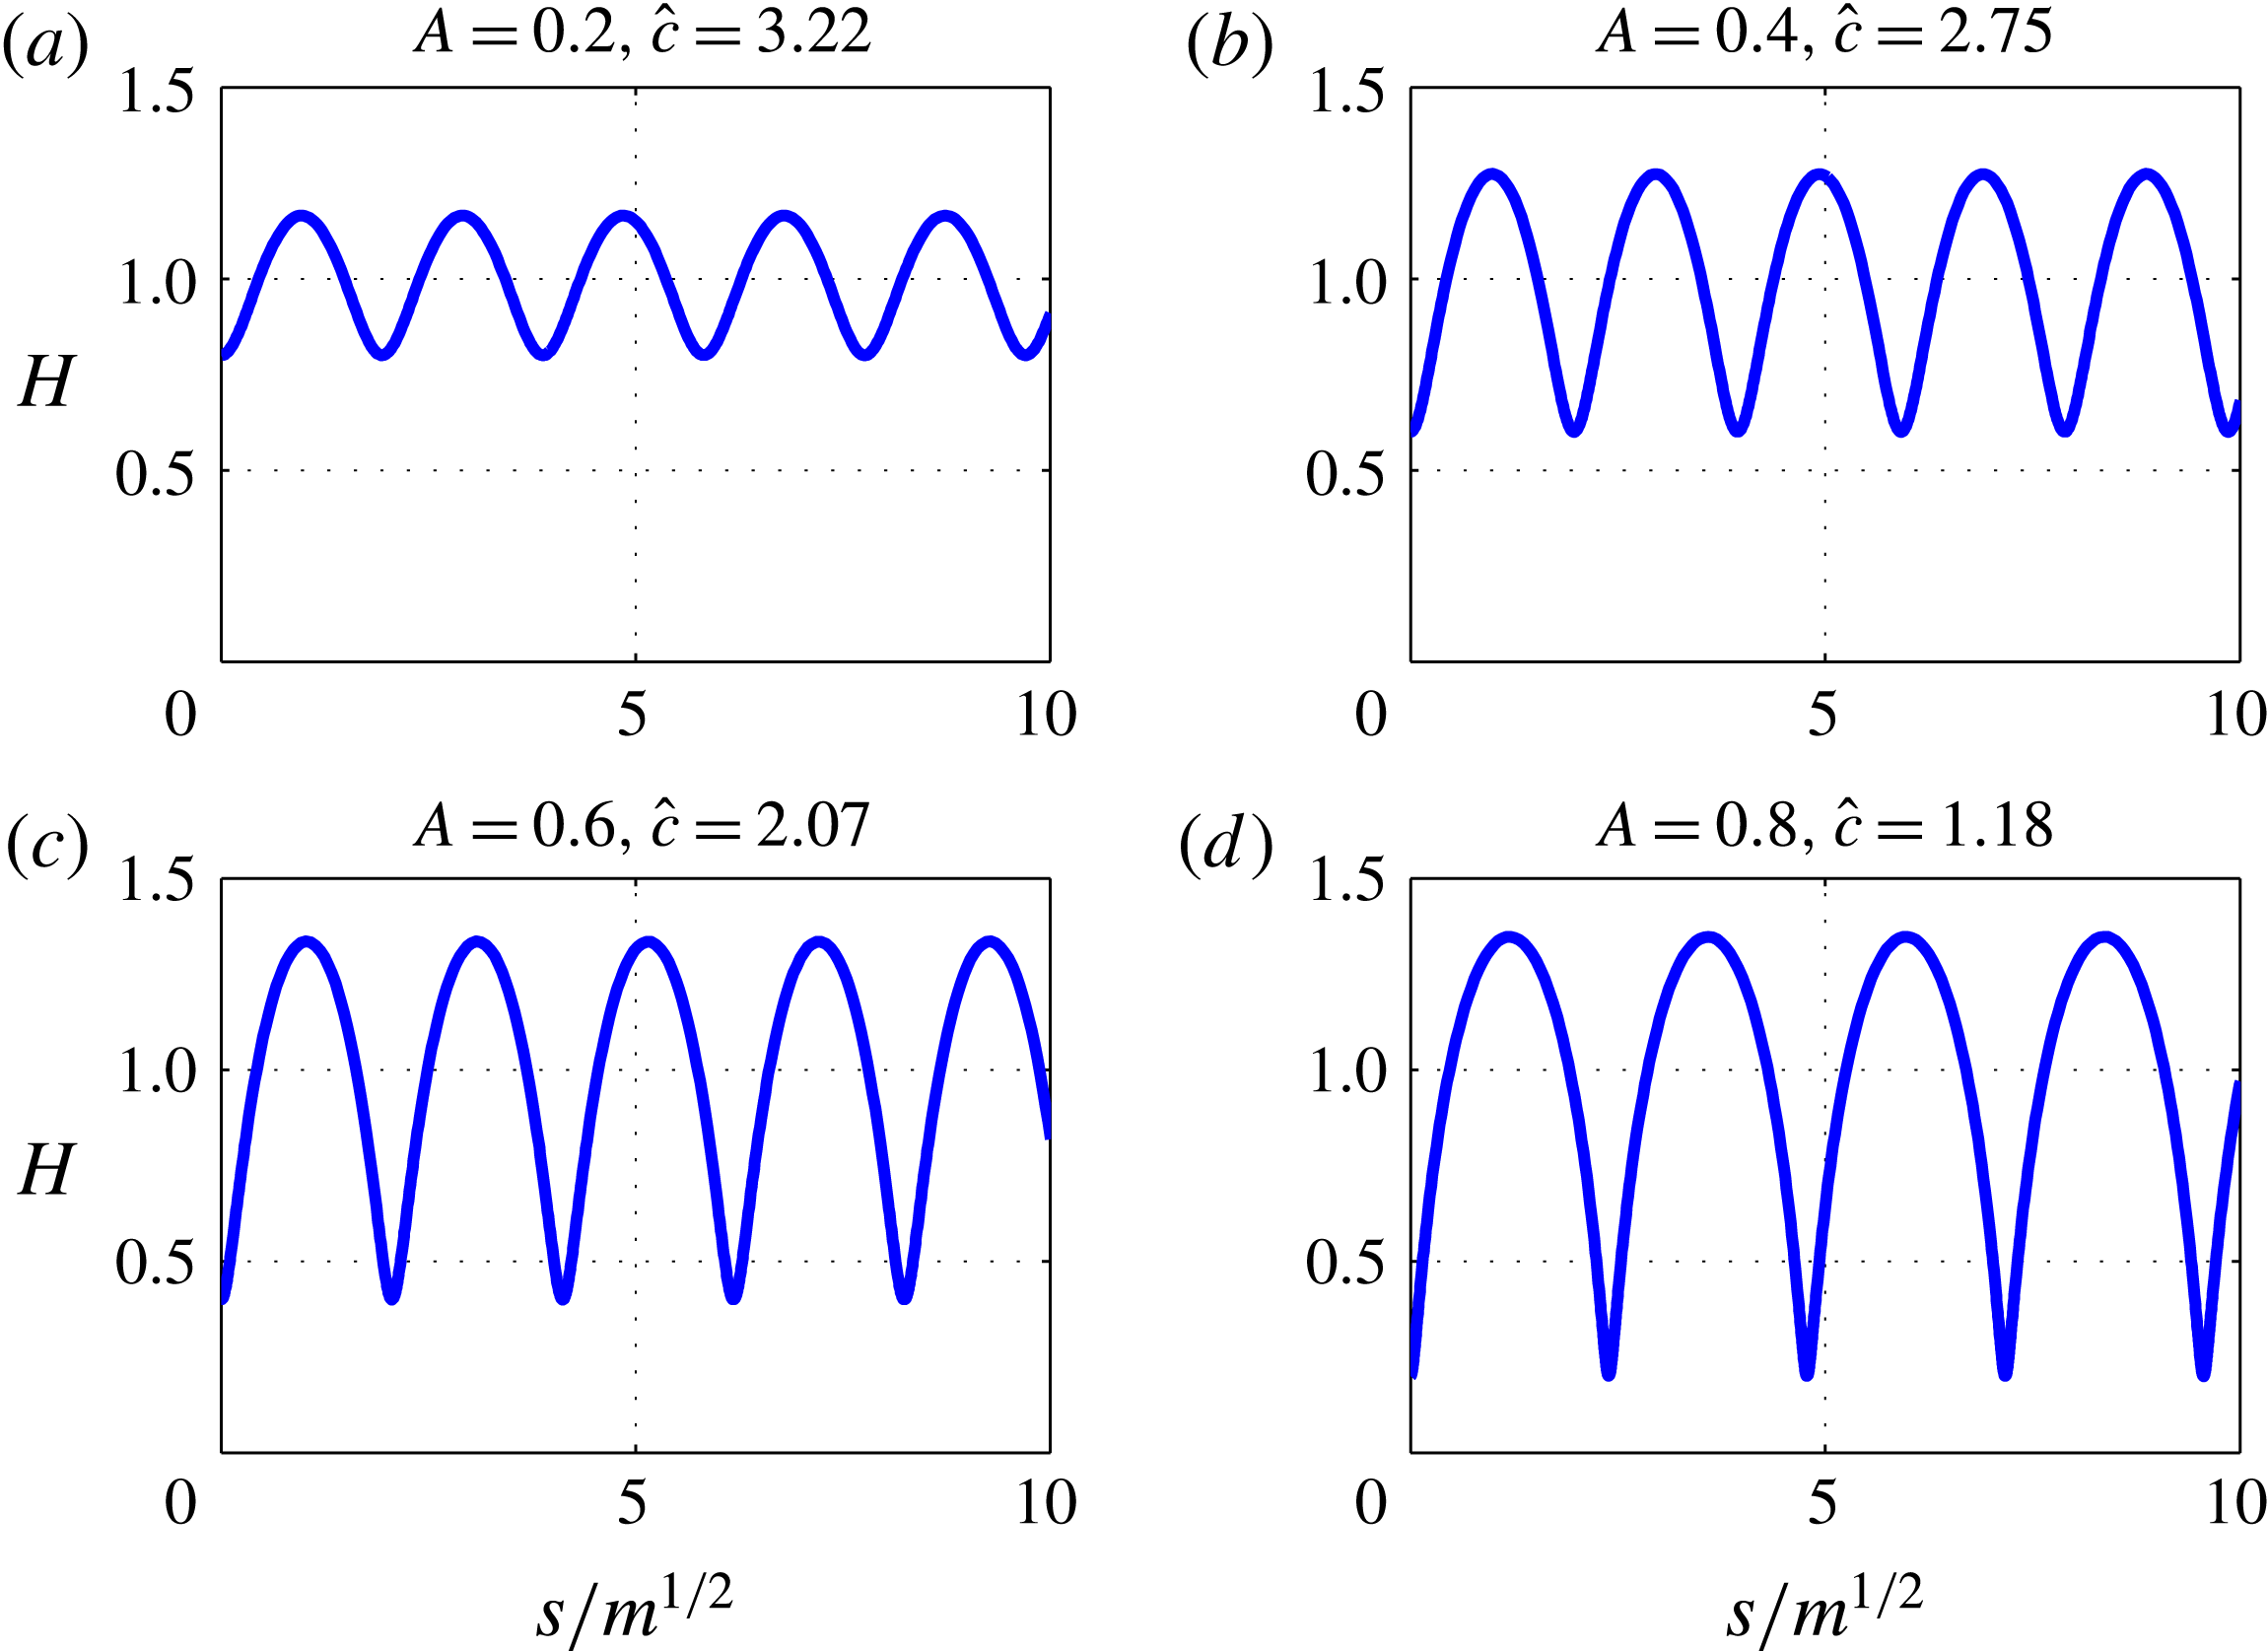
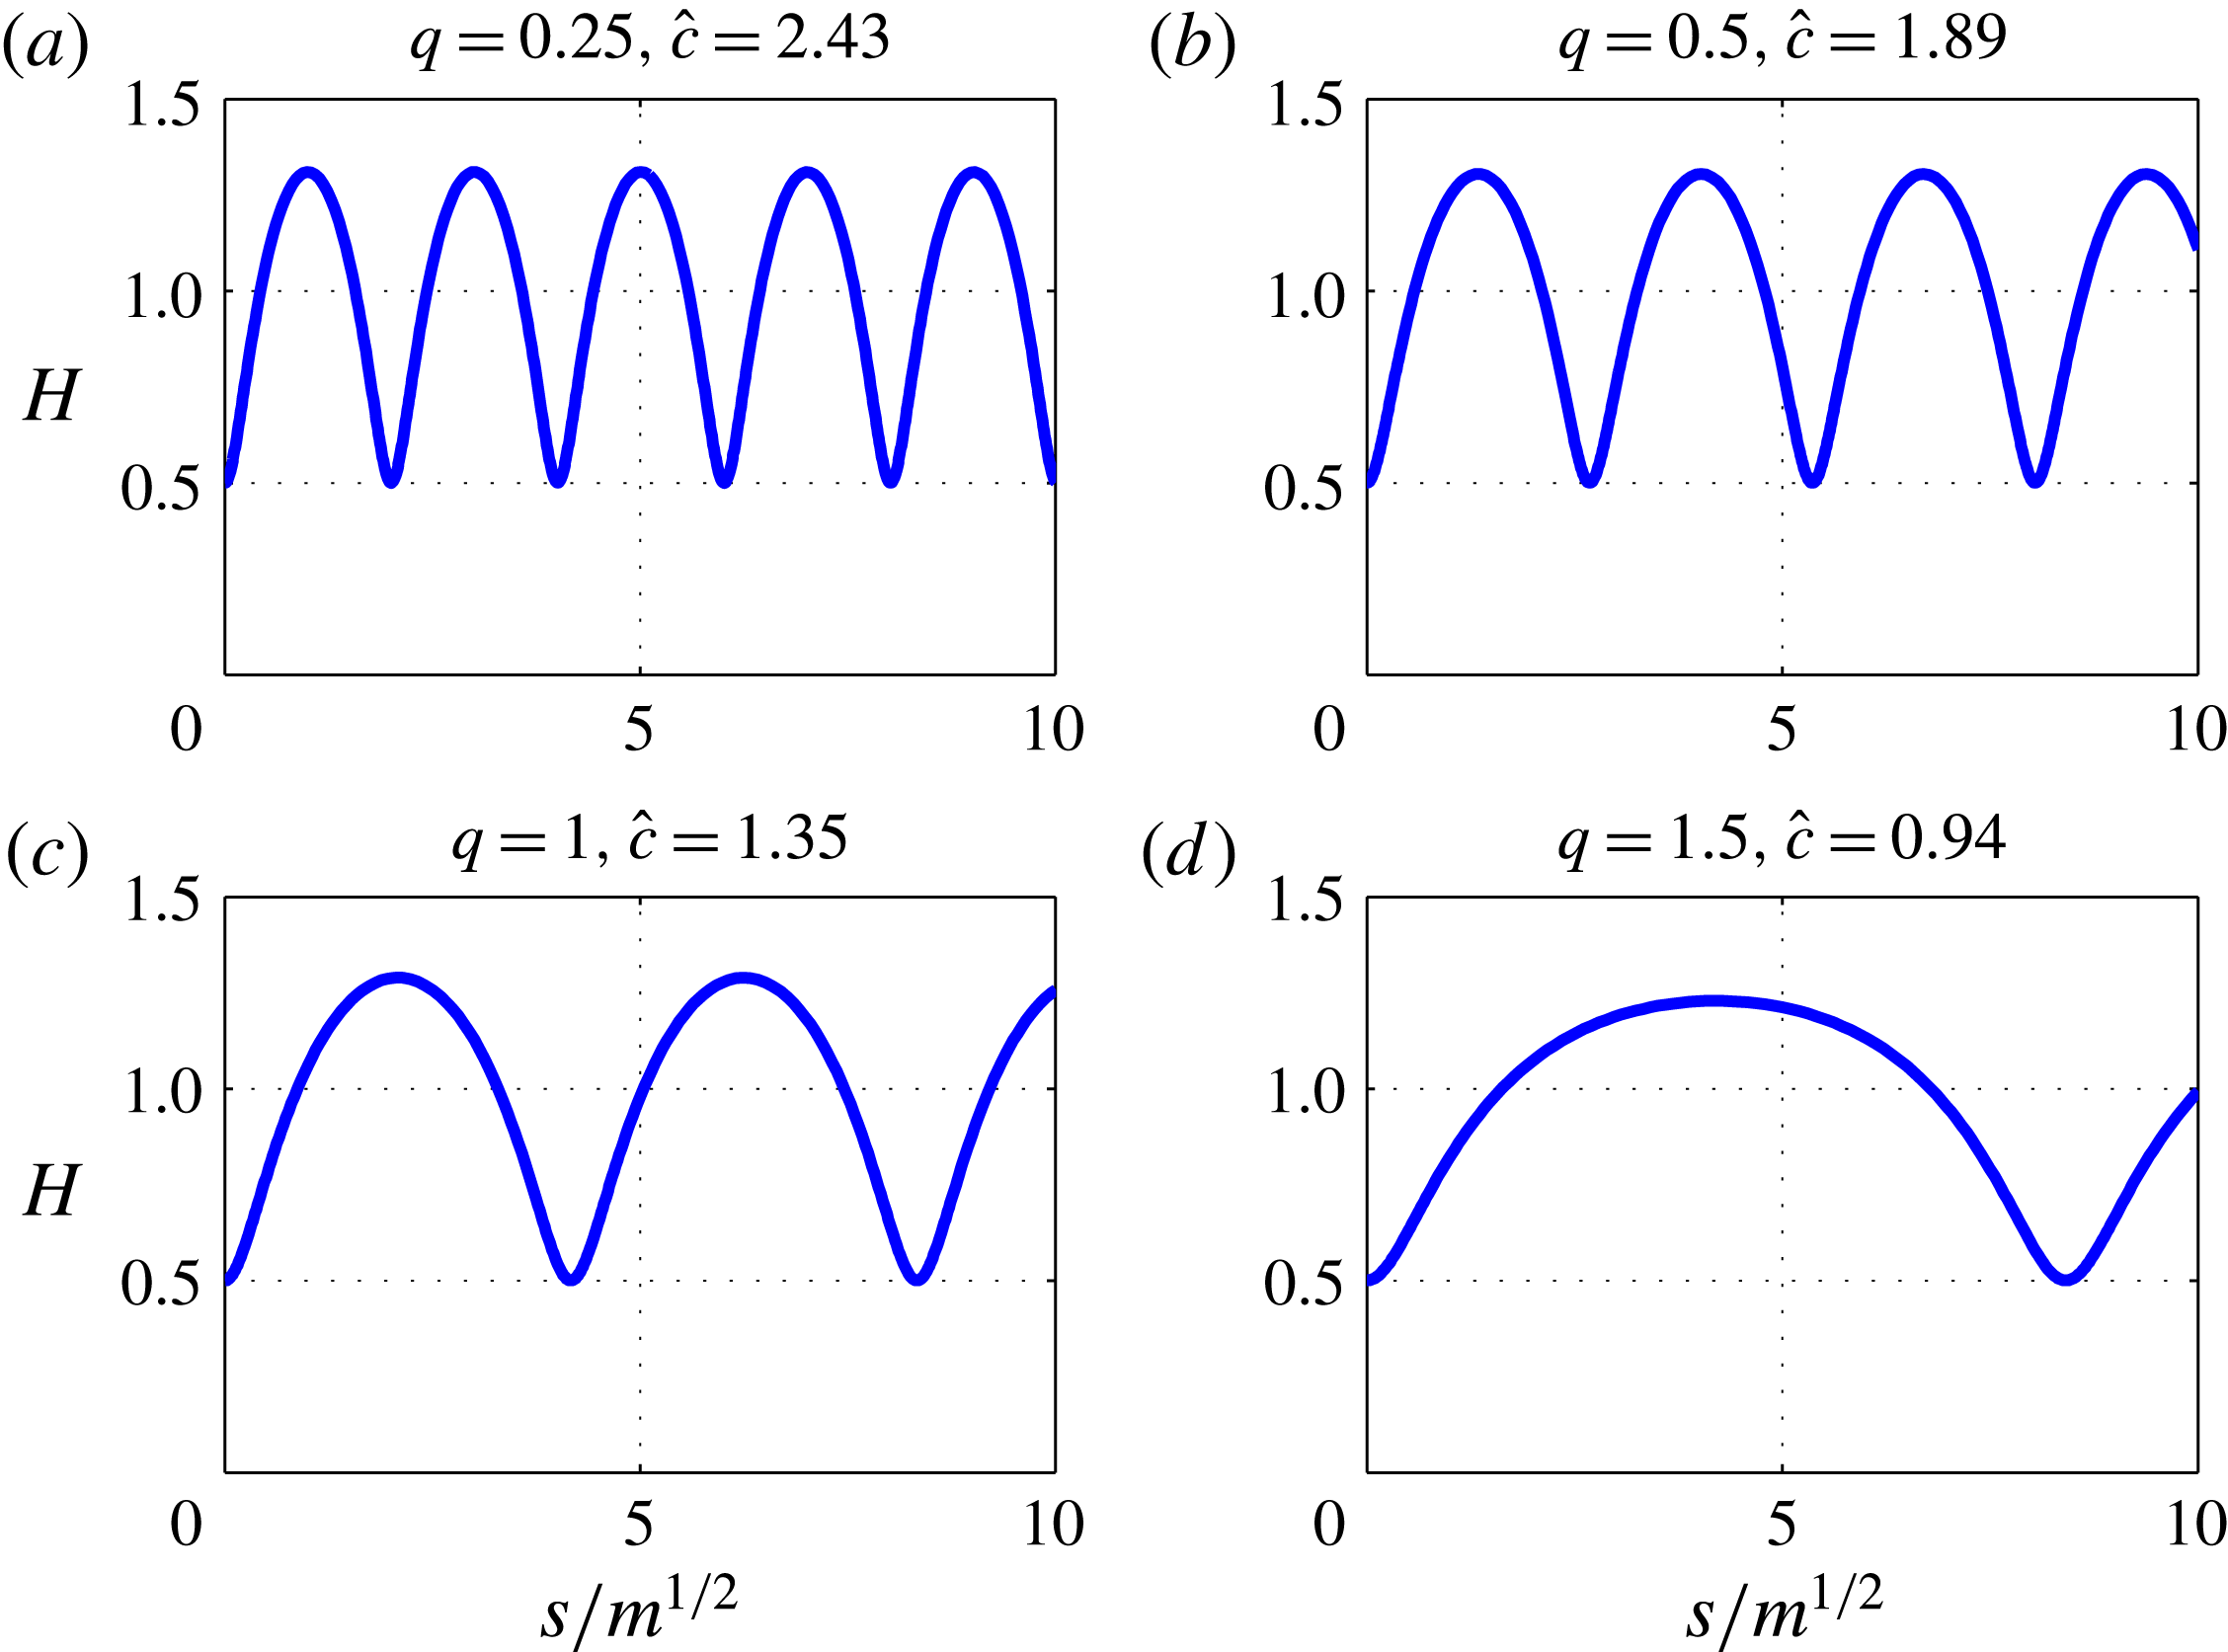
are indicated by circles in figure 4. Examples of the wave shapes for various values of
 $q$
and
 $A$
are shown in figures 6 and 7.
Periodic waves for
 $q=0.25$
and several values of the amplitude
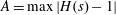 $A=\max |H(s)-1|$
;
 ${\hat{c}}=c/\sqrt{\unicode[STIX]{x1D6FE}_{0}}$
where
 $c$
is the wave speed.

Periodic waves of the same amplitude
 $A=0.5$
for several values of parameter
 $q$
.

5.3 Very strong vibration (
 $\unicode[STIX]{x1D6FE}_{0}=0$
)

In the case of
 $\unicode[STIX]{x1D6FE}_{0}=0$
, equation (5.12) can be rewritten as
 $$\begin{eqnarray}\left(HH^{\prime \prime }+\frac{{H^{\prime }}^{2}}{2}\right)=\frac{B^{\ast 2}}{2H^{2}}+H-C^{\ast },\end{eqnarray}$$
where (cf. (5.13))
 $$\begin{eqnarray}B^{\ast }=\frac{B}{\sqrt{\unicode[STIX]{x1D718}}},\quad C^{\ast }=\frac{C}{\unicode[STIX]{x1D718}}+\frac{c^{\ast 2}}{2},\quad c^{\ast }=\frac{c}{\sqrt{\unicode[STIX]{x1D718}}}.\end{eqnarray}$$
In terms of new variables
 $R$
and
 $\unicode[STIX]{x1D70E}$
, defined as (cf. (5.14))
 $$\begin{eqnarray}H(s)=\sqrt{\frac{B^{\ast 2}}{2C^{\ast }}}R^{2/3}(\unicode[STIX]{x1D70E}),\quad \unicode[STIX]{x1D70E}=\sqrt{\frac{2C^{\ast 2}}{B^{\ast 2}}}s.\end{eqnarray}$$
Equation (5.34) reduces to the equation of motion of a particle in a potential:
 $$\begin{eqnarray}R^{\prime \prime }(\unicode[STIX]{x1D70E})=-\hat{V}^{\prime }(R),\quad \hat{V}(R)={\textstyle \frac{9}{4}}(R^{-2/3}+R^{2/3}).\end{eqnarray}$$
Note that the potential
 $\hat{V}(R)$
does not contain free parameters. It has a global minimum at
 $R=1$
, so that only periodic motion of the particle is possible. As before, we restrict our attention to waves for which the mass flux,
 $M=HU$
, averaged over the period of the wave, is zero (
 $\langle M\rangle =0$
) and require that the mean depth is equal to
 $1$
(
 $\langle H\rangle =1$
). Let
 $$\begin{eqnarray}\unicode[STIX]{x1D706}=\sqrt{(2\hat{E}/9)^{2}-1},\end{eqnarray}$$
where
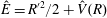 $\hat{E}={R^{\prime }}^{2}/2+\hat{V}(R)$
is the particle’s energy. Periodic solutions are possible for
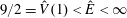 $9/2=\hat{V}(1)<\hat{E}<\infty$
. This implies that parameter
 $\unicode[STIX]{x1D706}$
, defined by (5.38), can vary from
 $0$
to
 $\infty$
. The equation of motion (5.37) can be integrated analytically, albeit in implicit form. (An integral, which is similar to (5.30), is computed using the change of the variable of integration:
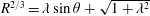 $R^{2/3}=\unicode[STIX]{x1D706}\sin \unicode[STIX]{x1D703}+\sqrt{1+\unicode[STIX]{x1D706}^{2}}$
.) Here we present only final results. It can be shown that the period,
 $S$
, and the amplitude,
 $A$
, can be expressed in terms of
 $\unicode[STIX]{x1D706}$
as
 $$\begin{eqnarray}S=\frac{2\unicode[STIX]{x03C0}}{c^{\ast }}\frac{(1+\unicode[STIX]{x1D706}^{2})^{3/2}}{\left(1+\frac{3}{2}\unicode[STIX]{x1D706}^{2}\right)^{2}},\quad A=\frac{\unicode[STIX]{x1D706}\sqrt{1+\unicode[STIX]{x1D706}^{2}}+\frac{1}{2}\unicode[STIX]{x1D706}^{2}}{1+\frac{3}{2}\unicode[STIX]{x1D706}^{2}}.\end{eqnarray}$$
The wave amplitude does not depend on the wave speed. It goes to
 $0$
as
 $\unicode[STIX]{x1D706}\rightarrow 0$
and to
 $1$
when
 $\unicode[STIX]{x1D706}\rightarrow \infty$
. The period (wavelength) is inversely proportional to the wave speed and tends to a non-zero limit, depending on
 $c^{\ast }$
, as
 $\unicode[STIX]{x1D706}\rightarrow 0$
and goes to
 $0$
when
 $\unicode[STIX]{x1D706}\rightarrow \infty$
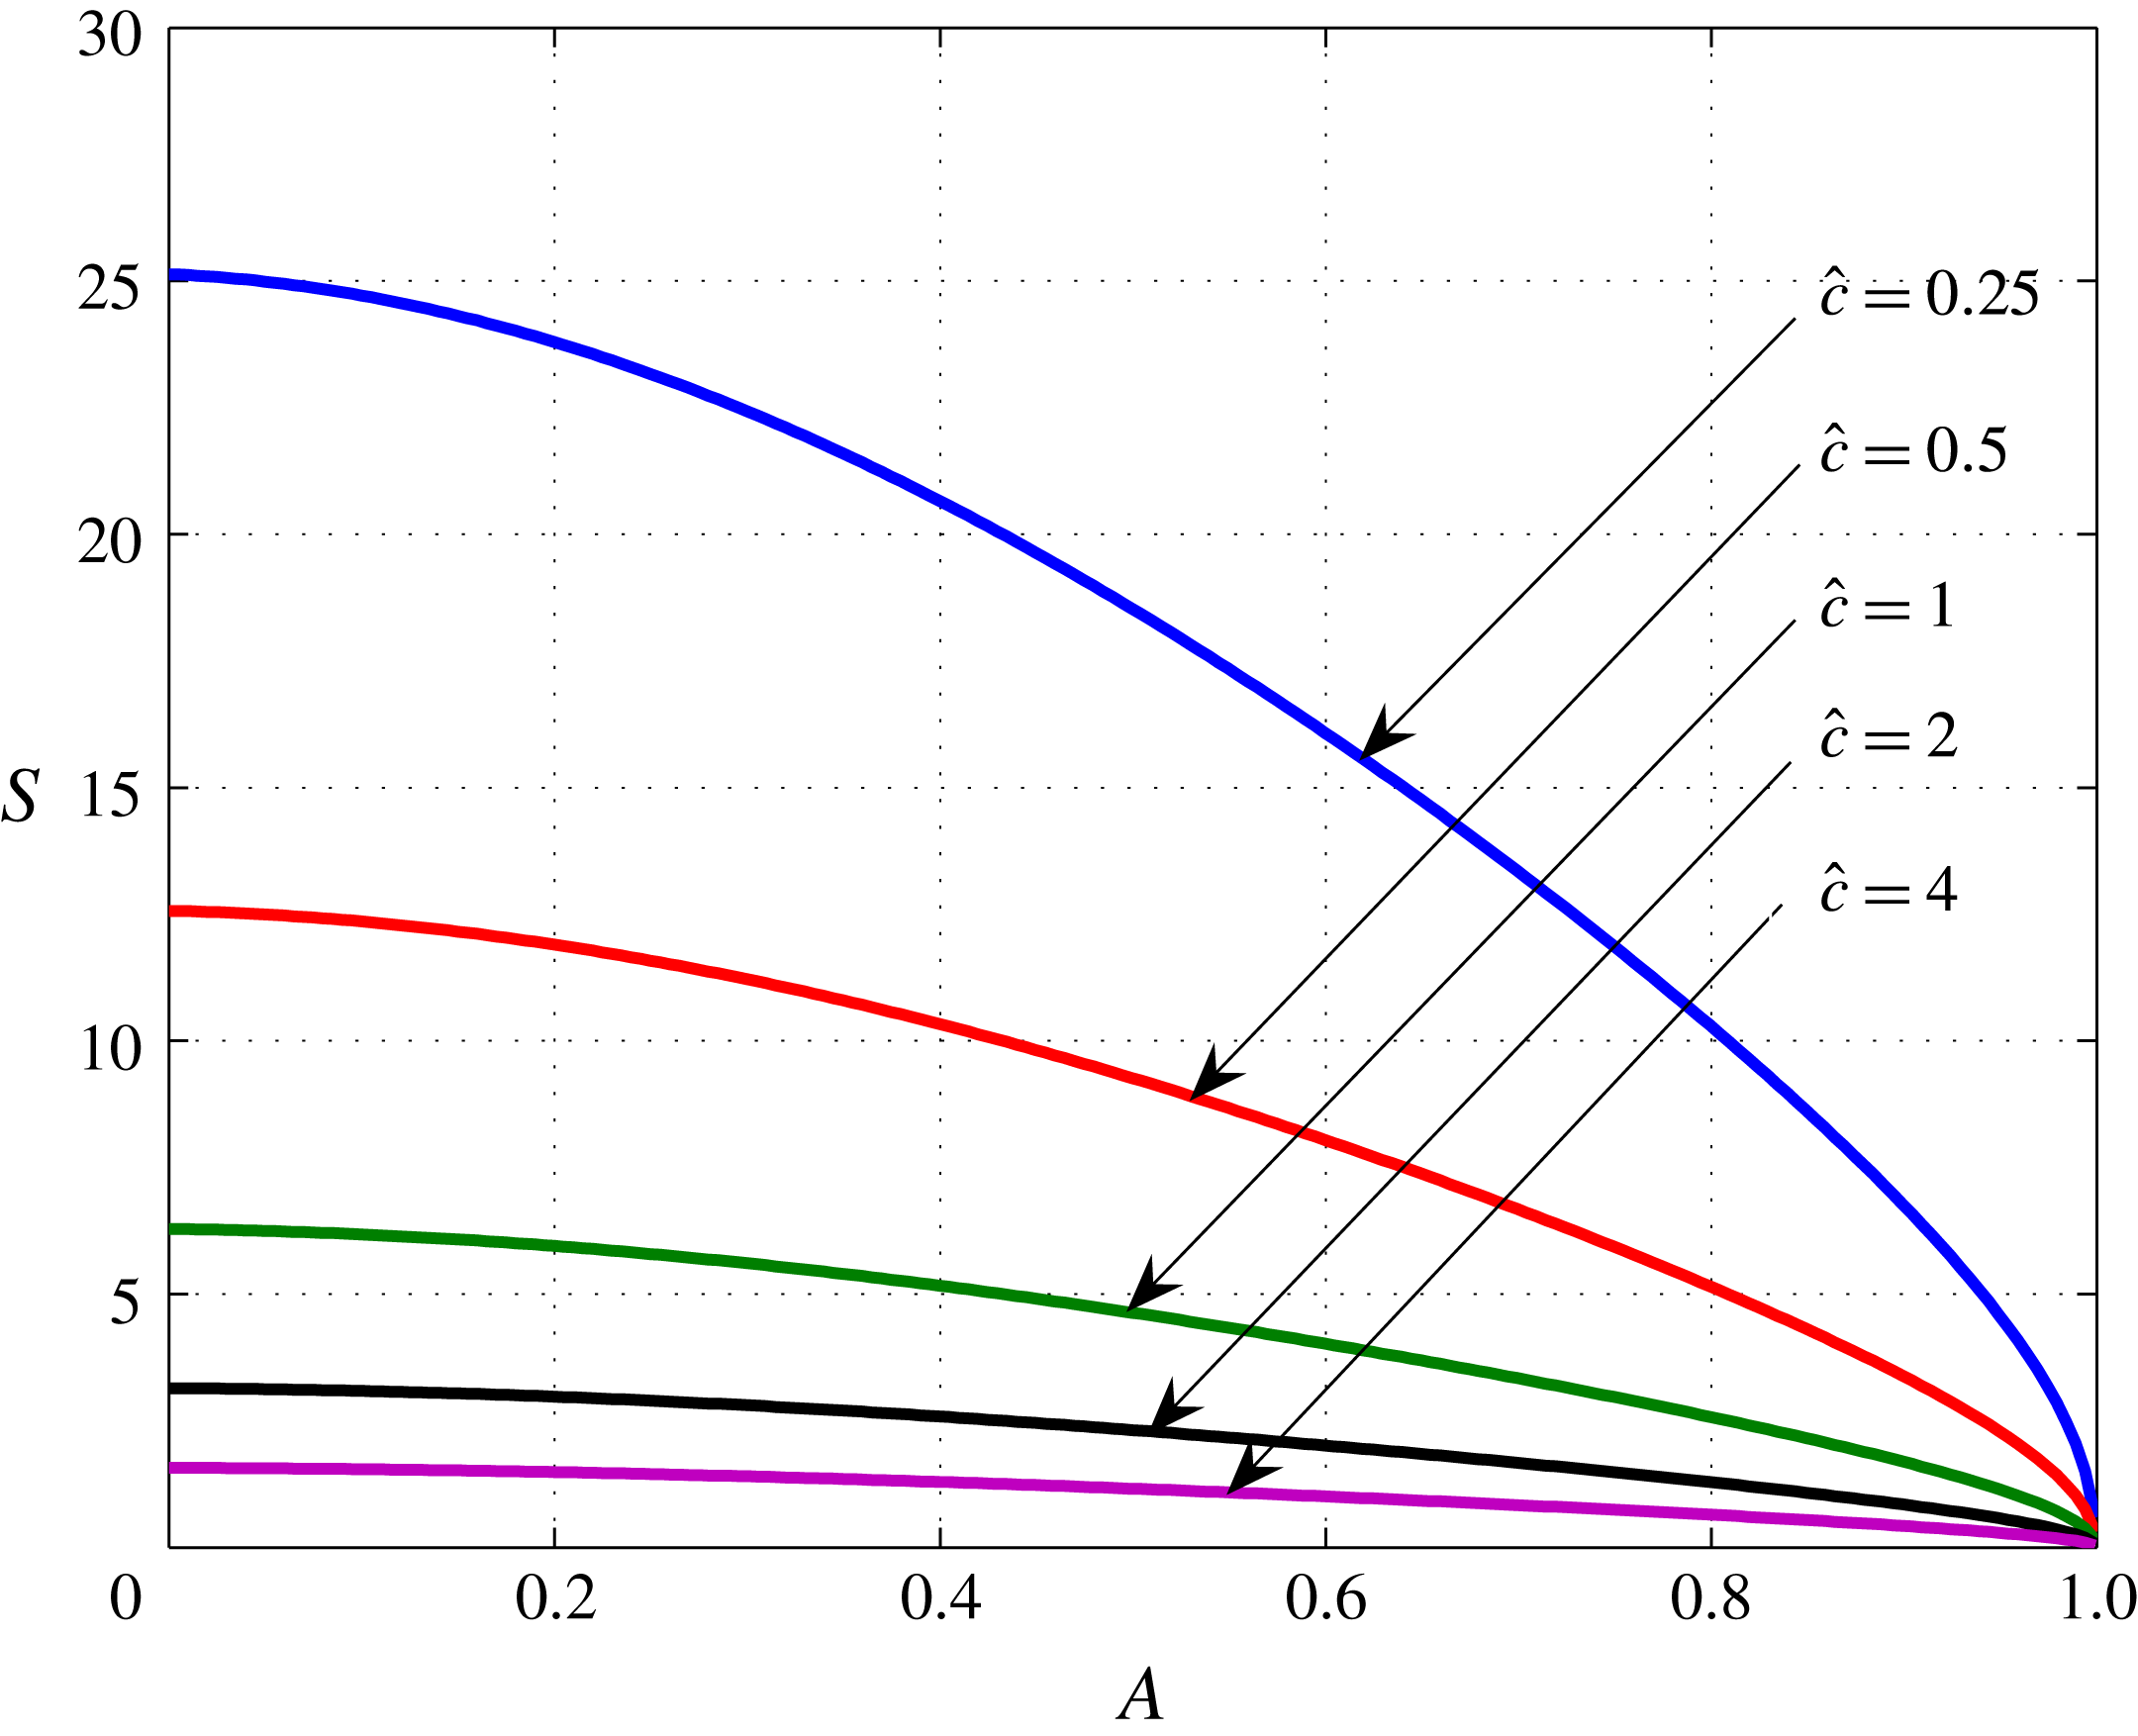
. For each
 $c^{\ast }$
, equation (5.39) defines a curve on the
 $(A,S)$
-plane. These curves for several values of the wave speed are shown in figure 8.
Periodic travelling waves for
 $\unicode[STIX]{x1D6FE}_{0}=0$
: the wavelength,
 $S$
, versus the amplitude,
 $A$
, for several values of the wave speed.

6 Discussion
We have considered free-surface waves in a layer of an inviscid fluid which is subject to vertical vibrations and derived three asymptotic models for slowly evolving nonlinear waves in the limit of high-frequency vibrations. This has been done by constructing asymptotic expansions of the exact governing equations for water waves using the method of multiple scales. All three expansions resulted in asymptotic equations that are nonlinear and valid for waves whose amplitude is of the same order of magnitude as the fluid depth and for vibrations of sufficiently high frequency such that the acceleration due to vibrations is much greater than the gravitational acceleration. In the first expansion, it was also assumed that the amplitude of the vibration is small (relative to the fluid depth). The asymptotic equations that emerge in this case are Hamiltonian and coincide with the standard equations for water waves in a non-vibrating fluid layer with an additional non-local nonlinear term representing the effect of the vibration. This leads to an extra term in the dispersion relation for linear waves, which, at least in the long-wave limit, is similar to what would happen if a surface tension was taken into account. The second and the third expansions employed the long-wave approximation. In the second one, it was assumed that the vibration amplitude was small, while in the third it was of the same order of magnitude as the fluid depth. Remarkably, these two quite different physical assumptions lead to the nonlinear equations that have exactly the same form. Again, the equations are Hamiltonian. If the vibration is absent, they reduce to the standard dispersionless shallow-water equations. The effect of the vibration appears as an extra nonlinear term which makes the equations dispersive and, for linear waves, is equivalent to surface tension.
It is not difficult to include genuine surface tension in the present theory. It can be shown (see appendix B) that, under appropriate assumptions about the Bond number, surface tension leads to an additional term in the asymptotic equations, which has a standard form (see appendix B).
The asymptotic analysis of the present paper suggests the following mechanism for the emergence of the ‘vibrational surface tension’ effect. Relative to the reference frame oscillating with the bottom, the unperturbed free surface is flat and not moving. In the limit of high frequency, when the free surface is perturbed, the free-surface elevation,
 $\unicode[STIX]{x1D702}$
, is the sum of a slowly varying finite-amplitude part and a rapidly oscillating small-amplitude part. Note that both the slowly varying and oscillating parts of the velocity have finite amplitude and that the oscillating part of the velocity potential is proportional to the slowly varying part of
 $\unicode[STIX]{x1D702}$
. The ‘surface tension’ arises from averaging the product of the vibrational acceleration
 $f^{\prime \prime }(\unicode[STIX]{x1D70F})$
and the oscillatory part of
 $\unicode[STIX]{x1D702}$
. The latter is determined by the oscillating part of the vertical velocity of the free surface, which, for long waves, is proportional to the horizontal Laplacian of the slowly varying part of
 $\unicode[STIX]{x1D702}$
, thus yielding the ‘vibrational surface tension’ term. It is therefore clear that (i) this effect appears only if the frequency of the vibration is sufficiently high and (ii) it affects only long waves. The latter fact explains the vibrational stabilisation of the Rayleigh–Taylor instability, where the most unstable modes are associated with long waves. This conclusion is consistent with earlier results of Lapuerta et al. (Reference Lapuerta, Mancebo and Vega2001).
The analysis of one-dimensional waves has shown that the asymptotic equations have travelling solitary and periodic wave solutions. The solitary waves are depression waves and have wave speed smaller than that of gravity waves (subcritical waves). This resembles the capillary–gravity depression waves that were predicted first by Korteweg & de Vries (Reference Korteweg and de Vries1895), later considered again by Benjamin (Reference Benjamin1982) and Vanden-Broeck & Shen (Reference Vanden-Broeck and Shen1983) and recently observed in experiments by Falcon et al. (Reference Falcon, Laroche and Fauve2002). Our equations have neither solution in the form of elevation solitary waves, nor solitary wave solutions propagating with the speed higher than that of gravity waves (which is different from the capillary–gravity waves in a non-vibrating fluid where such waves exist). At the moment, the reason for the non-existence of elevation waves it is not quite clear: it may be related to the approximate nature of the model equations or it may be a generic property of the waves in vibrating fluid. This question requires a further investigation.
We have also shown that the asymptotic equations have many periodic travelling wave solution and that the solitary waves can be viewed as the limit of periodic waves as the wavelength of the latter is continuously increased. It has also been shown that if the vibration completely dominates over the gravity, the travelling wave solutions of the asymptotic equations can be found analytically and that only periodic waves are possible in this case.
Here we did not consider weakly nonlinear waves in the vibrating fluid layer. An interesting open question that arises in this context is whether there are slowly varying waves that can be described by the standard Korteweg–de Vries equation or if some other equation will emerge. This is a subject of a continuing investigation.
It would be interesting to verify the theory in experiments. To observe solitary waves, it is necessary to apply vibrations to a long channel which is difficult to realise experimentally. However, it may be possible to observe standing periodic waves in a container of a reasonable size. For example, consider a water layer of depth 1 cm, which is forced to vibrate vertically with amplitude 1 mm and frequency 160 Hz. This corresponds to
 $\unicode[STIX]{x1D6FE}=100$
,
 $\unicode[STIX]{x1D6FC}=0.1$
and
 $\unicode[STIX]{x1D707}=0.1$
, and this case is covered by the model of § 4.1. If now the vibrating free surface is forced periodically with low frequency (of approximately 10–20 Hz), this will produce long standing waves for certain values of the forcing frequency which can be predicted using the theory developed in this paper. The size of the container should cover a few long wavelengths, where a long wavelength means approximately 10 cm, so that a container of width 10 cm and length 50–70 cm is a suitable candidate for this experiment.
Acknowledgements
The author is grateful to Professors S. L. Gavrilyuk, A. B. Morgulis and M. Yu. Zhukov and for interesting and useful discussions.
Appendix A
Here we describe how the asymptotic expansion, given by (4.24)–(4.27), is derived. We seek an expansion in the form
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D719}=\unicode[STIX]{x1D719}_{0}(x,y,z,\unicode[STIX]{x1D70F},t)+\unicode[STIX]{x1D716}\unicode[STIX]{x1D719}_{1}(x,y,z,\unicode[STIX]{x1D70F},t)+\cdots \,,\quad \unicode[STIX]{x1D702}=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t)+\unicode[STIX]{x1D716}\unicode[STIX]{x1D702}_{1}(x,y,\unicode[STIX]{x1D70F},t)+\cdots & & \displaystyle \nonumber\\ \displaystyle & & \displaystyle\end{eqnarray}$$
where
 $t=\unicode[STIX]{x1D716}\unicode[STIX]{x1D70F}$
is the slow time. Substituting these in (4.20)–(4.23) and collecting terms of the same order in
 $\unicode[STIX]{x1D716}$
, we obtain the following sequence of equations:
at leading order,
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{0zz}=0\quad \text{for }-1<z<\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{0\unicode[STIX]{x1D70F}}+f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{0}+\frac{\unicode[STIX]{x1D719}_{0z}^{2}}{2}=0\quad \text{at }z=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{0z}=0\quad \text{at }z=-1, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}_{0\unicode[STIX]{x1D70F}}=\unicode[STIX]{x1D719}_{0z}\quad \text{at }z=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t); & \displaystyle\end{eqnarray}$$
at first order,
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D719}_{1zz}=-\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D719}_{0}\quad \text{for }-1<z<\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t), & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & & \displaystyle \unicode[STIX]{x1D719}_{1\unicode[STIX]{x1D70F}}+f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{1}+\unicode[STIX]{x1D719}_{0z\unicode[STIX]{x1D70F}}\unicode[STIX]{x1D702}_{1}+\unicode[STIX]{x1D719}_{0z}\unicode[STIX]{x1D719}_{1z}\nonumber\\ \displaystyle & & \displaystyle +\,\unicode[STIX]{x1D719}_{0z}\unicode[STIX]{x1D719}_{0zz}\unicode[STIX]{x1D702}_{1}+\unicode[STIX]{x1D719}_{0t}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}_{0}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\unicode[STIX]{x1D702}_{0}=0\quad \text{at }z=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t),\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{1z}=0\quad \text{at }z=-1, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}_{1\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D702}_{0t}+\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D702}_{0}=\unicode[STIX]{x1D719}_{1z}+\unicode[STIX]{x1D719}_{0zz}\unicode[STIX]{x1D702}_{1}\quad \text{at }z=\unicode[STIX]{x1D702}_{0}(x,y,\unicode[STIX]{x1D70F},t); & \displaystyle\end{eqnarray}$$
etc.
Leading-order equations. Equations (A 2) and (A 4) imply that
 $\unicode[STIX]{x1D719}_{0}$
does not depend on
 $z$
, i.e.
 $$\begin{eqnarray}\unicode[STIX]{x1D719}_{0}=\unicode[STIX]{x1D719}_{0}(x,y,\unicode[STIX]{x1D70F},t),\end{eqnarray}$$
which means that, at leading order, the vertical velocity is zero, and the horizontal velocity is homogeneous across the fluid layer. Now we deduce from (A 5) and (A 10) that
 $\unicode[STIX]{x1D702}$
does not depend on the fast time
 $\unicode[STIX]{x1D70F}$
:
 $$\begin{eqnarray}\unicode[STIX]{x1D702}_{0}=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t).\end{eqnarray}$$
In view of (A 10) and (A 11), equation (A 3) reduces to
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D719}_{0\unicode[STIX]{x1D70F}}+f^{\prime \prime }(\unicode[STIX]{x1D70F})\overline{\unicode[STIX]{x1D702}}_{0}=0\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t), & & \displaystyle\end{eqnarray}$$
from which we determine the oscillatory part of
 $\unicode[STIX]{x1D719}_{0}$
at
 $z=\overline{\unicode[STIX]{x1D702}}_{0}$
:
 $$\begin{eqnarray}\tilde{\unicode[STIX]{x1D719}}_{0}=-f^{\prime }(\unicode[STIX]{x1D70F})\overline{\unicode[STIX]{x1D702}}_{0}.\end{eqnarray}$$
First-order equations. We start with (A 6). Its most general solution that satisfies the boundary condition (A 8) is given by
 $$\begin{eqnarray}\unicode[STIX]{x1D719}_{1}=-\left(\frac{z^{2}}{2}+z\right)\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D719}_{0}(x,y,\unicode[STIX]{x1D70F},t)+B(x,y,\unicode[STIX]{x1D70F},t)\end{eqnarray}$$
for an arbitrary function
 $B$
.
Consider now (A 7) and (A 9). With the help of (A 10) and (A 11), these can be written as
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{1\unicode[STIX]{x1D70F}}+f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{1}+\unicode[STIX]{x1D719}_{0t}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}_{0}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\overline{\unicode[STIX]{x1D702}}_{0}=0\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D702}_{1\unicode[STIX]{x1D70F}}+\overline{\unicode[STIX]{x1D702}}_{0t}+\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}=\unicode[STIX]{x1D719}_{1z}\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t). & \displaystyle\end{eqnarray}$$
Averaging yields
 $$\begin{eqnarray}\displaystyle & \displaystyle \overline{\unicode[STIX]{x1D719}}_{0t}+\overline{f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{1}}+\frac{\overline{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}_{0}|^{2}}}{2}+\unicode[STIX]{x1D6FE}_{0}\overline{\unicode[STIX]{x1D702}}_{0}=0\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \overline{\unicode[STIX]{x1D702}}_{0t}+\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D719}}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}=\overline{\unicode[STIX]{x1D719}}_{1z}\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t). & \displaystyle\end{eqnarray}$$
The oscillatory part of (A 16) gives us the equation
 $$\begin{eqnarray}\displaystyle \tilde{\unicode[STIX]{x1D702}}_{1\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D735}_{\shortparallel }\tilde{\unicode[STIX]{x1D719}}_{0}\boldsymbol{\cdot }\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}=\tilde{\unicode[STIX]{x1D719}}_{1z}\quad \text{at }z=\overline{\unicode[STIX]{x1D702}}_{0}(x,y,t), & & \displaystyle\end{eqnarray}$$
which, with the help of (A 13) and (A 14), can be written as
 $$\begin{eqnarray}\tilde{\unicode[STIX]{x1D702}}_{1\unicode[STIX]{x1D70F}}=f^{\prime }(\unicode[STIX]{x1D70F})[|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}|^{2}+(1+\overline{\unicode[STIX]{x1D702}}_{0})\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\overline{\unicode[STIX]{x1D702}}_{0}].\end{eqnarray}$$
It follows from (A 13), (A 14) and (A 20) that
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \overline{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}_{0}|^{2}}=|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D719}}_{0}|^{2}+\overline{|\unicode[STIX]{x1D735}_{\shortparallel }\tilde{\unicode[STIX]{x1D719}}_{0}|^{2}}=|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D719}}_{0}|^{2}+\unicode[STIX]{x1D718}|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}|^{2},\\ \displaystyle \overline{\unicode[STIX]{x1D719}}_{1z}|_{z=\overline{\unicode[STIX]{x1D702}}_{0}}=-(\overline{\unicode[STIX]{x1D702}}_{0}+1)\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\overline{\unicode[STIX]{x1D719}}_{0},\\ \displaystyle \overline{f^{\prime \prime }(\unicode[STIX]{x1D70F})\unicode[STIX]{x1D702}_{1}}=-\overline{f^{\prime }(\unicode[STIX]{x1D70F})\tilde{\unicode[STIX]{x1D702}}_{1\unicode[STIX]{x1D70F}}}=-\unicode[STIX]{x1D718}[(1+\overline{\unicode[STIX]{x1D702}}_{0})\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\overline{\unicode[STIX]{x1D702}}_{0}+|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}|^{2}].\end{array}\right\} & & \displaystyle\end{eqnarray}$$
Finally, substituting these into (A 17) and (A 18), we obtain a closed system of averaged equations which can be written in the form
 $$\begin{eqnarray}\displaystyle & \displaystyle \overline{\unicode[STIX]{x1D719}}_{0t}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D719}}_{0}|^{2}}{2}+\unicode[STIX]{x1D6FE}_{0}\overline{\unicode[STIX]{x1D702}}_{0}-\unicode[STIX]{x1D718}\left[(1+\overline{\unicode[STIX]{x1D702}}_{0})\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\overline{\unicode[STIX]{x1D702}}_{0}+\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D702}}_{0}|^{2}}{2}\right]=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \overline{\unicode[STIX]{x1D702}}_{0t}+\unicode[STIX]{x1D735}_{\shortparallel }\boldsymbol{\cdot }[(1+\overline{\unicode[STIX]{x1D702}}_{0})\unicode[STIX]{x1D735}_{\shortparallel }\overline{\unicode[STIX]{x1D719}}_{0}]=0, & \displaystyle\end{eqnarray}$$
where
 $\unicode[STIX]{x1D718}$
is defined by (3.38). If we now use the notation
 $\unicode[STIX]{x1D713}=\overline{\unicode[STIX]{x1D719}}_{0}$
,
 $\unicode[STIX]{x1D701}=\overline{\unicode[STIX]{x1D702}}_{0}$
and
 $\unicode[STIX]{x1D718}$
, we get (4.26) and (4.27).
Appendix B
Here we briefly discuss the effects of surface tension. With surface tension taken into account, the dynamical condition of the free surface, given by (2.5), becomes
 $$\begin{eqnarray}\unicode[STIX]{x1D719}_{\unicode[STIX]{x1D70F}}+\unicode[STIX]{x1D6FC}\left(\unicode[STIX]{x1D707}^{2}\frac{|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D719}|^{2}}{2}+\frac{\unicode[STIX]{x1D719}_{z}^{2}}{2}\right)+\unicode[STIX]{x1D6FD}[\unicode[STIX]{x1D6FE}+f^{\prime \prime }(\unicode[STIX]{x1D70F})]\unicode[STIX]{x1D702}=\frac{\unicode[STIX]{x1D6FD}\unicode[STIX]{x1D707}^{2}\unicode[STIX]{x1D6FE}}{Bo}\unicode[STIX]{x1D735}_{\shortparallel }\boldsymbol{\cdot }\left[\frac{\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D702}}{\sqrt{1+\unicode[STIX]{x1D6FD}^{2}\unicode[STIX]{x1D707}^{2}|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D702}|^{2}}}\right],\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6FC}$
,
 $\unicode[STIX]{x1D6FD}$
,
 $\unicode[STIX]{x1D6FE}$
and
 $\unicode[STIX]{x1D707}$
are the dimensionless parameters defined in § 2 and
 $Bo$
is the Bond number introduced in § 1. In what follows,
 $\unicode[STIX]{x1D6FD}=1$
(as was assumed for all the asymptotic models). The dimensionless coefficient of the surface tension term on the right-hand side of (B 1) is proportional to both
 $\unicode[STIX]{x1D707}^{2}$
and
 $\unicode[STIX]{x1D6FE}$
, and the surface tension term will appear in the asymptotic equations only if it is at least of the same order of magnitude as
 $\unicode[STIX]{x1D6FE}$
. This implies that
 $\unicode[STIX]{x1D707}^{2}$
and
 $Bo$
must be of the same order.
Consider first the model of § 3 (no long-wave approximation). So, let
 $\unicode[STIX]{x1D707}=1$
,
 $Bo=O(1)$
and the assumptions (3.1) hold. Then, the asymptotic procedure of § 3 yields the averaged equations (3.42) and (3.43) with an additional term on the right-hand side of (3.42), given by
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x1D6FE}_{0}}{Bo}\unicode[STIX]{x1D735}_{\shortparallel }\boldsymbol{\cdot }\left[\frac{\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}}{\sqrt{1+|\unicode[STIX]{x1D735}_{\shortparallel }\unicode[STIX]{x1D701}|^{2}}}\right]. & & \displaystyle\end{eqnarray}$$
This is the standard surface tension term for gravity–capillary waves.
For the long-wave models,
 $\unicode[STIX]{x1D707}^{2}\ll 1$
, so that
 $Bo$
must be small (
 $Bo\sim \unicode[STIX]{x1D707}^{2}\ll 1$
). This may be difficult to achieve experimentally. Nevertheless, let us consider the shallow-water models derived in this paper assuming that
 $Bo=B\unicode[STIX]{x1D707}^{2}$
where
 $B=O(1)$
as
 $\unicode[STIX]{x1D707}\rightarrow 0$
. If we consider vibrations of finite amplitude and adopt the assumptions (4.19), then we obtain the shallow-water equations (4.26) and (4.27) with the following additional term on the right-hand side of (4.26):
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x1D6FE}_{0}}{B}\unicode[STIX]{x1D6FB}_{\shortparallel }^{2}\unicode[STIX]{x1D701}, & & \displaystyle\end{eqnarray}$$
which is the same as the surface tension term for gravity–capillary waves of small amplitude. If the assumptions (4.16) (vibrations of small amplitude) were adopted, we would get exactly the same equations with
 $\unicode[STIX]{x1D6FE}_{0}$
replaced by
 $\unicode[STIX]{x1D6E4}$
.