


1 Introduction
Water waves (Stokes Reference Stokes1847) exhibit different types of instabilities, such as the sideband instability described by Benjamin & Feir (Reference Benjamin and Feir1967). In his study on the instability of finite amplitude water waves, Saffman (Reference Saffman1985) proved a general result regarding the instability of travelling wave solutions to canonical Hamiltonian systems subject to superharmonic perturbations, i.e. perturbations that are periodic in the wavelength of the travelling wave. He showed that any travelling wave solution would lose stability at those wave speeds representing stationary points of the energy whenever the underlying Hamiltonian system exhibited symmetry under translation and reflection of the wave profile. Here, translational and reflectional symmetry are defined as invariance of wave solutions under the exchanges
 $x^{\prime }\rightarrow x^{\prime }+\unicode[STIX]{x1D709}$
and
 $x^{\prime }\rightarrow -x^{\prime }$
, respectively, where
 $\unicode[STIX]{x1D709}\in \mathbb{R}$
is a constant and
 $x^{\prime }$
is the spatial coordinate of a reference frame moving with the phase speed
 $\boldsymbol{c}$
of the travelling wave and with the
 $x^{\prime }$
-axis oriented along
 $\boldsymbol{c}$
. Saffman’s purpose was to explain a numerical result found by Tanaka (Reference Tanaka1983), who observed the destabilization of a steep gravity wave at the maximum of the energy with respect to wave speed. Tanaka’s observation was unexpected because it conflicted with the conjecture made by Longuet-Higgins (Reference Longuet-Higgins1978) in the first work on the topic. Indeed, based on numerical evidence up to the wave steepness
 $ak=0.42$
, Longuet-Higgins suggested that superharmonic instability would first occur at the wave steepness
 $ak=0.436$
(a wave height to wavelength ratio of
 $h/\unicode[STIX]{x1D706}=0.1388$
) corresponding to the maximum wave speed. The discrepancy between Tanaka’s result and Longuet-Higgins’ conjecture was due to the poor convergence of the numerical scheme adopted by Longuet-Higgins at large steepness. Tanaka (Reference Tanaka1985) later showed that the eigenvectors associated with the first two modes of oscillation become linearly dependent at the critical point, corroborating bifurcation analysis of Chen & Saffman (Reference Chen and Saffman1980) and Longuet-Higgins (Reference Longuet-Higgins1984). Using Zakharov’s Hamiltonian formulation of the water wave problem (Zakharov Reference Zakharov1968; Zakharov & Kuznetsov Reference Zakharov and Kuznetsov1997), Saffman performed a linear stability analysis of a travelling wave with reflectionally symmetric profile, i.e. a profile such that
 $\boldsymbol{A}=\boldsymbol{A}^{\ast }$
, with
 $\boldsymbol{A}$
and
 $\boldsymbol{A}^{\ast }$
the steady values of the canonical variables of the system in a frame comoving with the wave (see equation (6) of Saffman (Reference Saffman1985)), and analytically proved that the zero eigenvalue arising from the translational symmetry of the solutions had algebraic multiplicity equal or greater than four at stationary points of the energy. In practical terms, this behaviour, referred to as exchange of stability (see Saffman Reference Saffman1985; Crawford Reference Crawford1991), indicates the onset of unstable growing modes that eventually destabilize the travelling wave. This mechanism can be understood as follows. Due to the Hamiltonian nature of dynamics, eigenvalues are paired. The zero eigenvalue, which has even algebraic multiplicity equal or greater than two, physically correspond to a phase shift of the translationally symmetric fundamental mode of oscillation. When a purely imaginary eigenvalue crosses the zero eigenvalue at stationary points of energy, the square of the purely imaginary eigenvalue undergoes a sign flip. This change of sign determines the transition of the imaginary eigenvalue to the unstable real domain (see for example Longuet-Higgins (Reference Longuet-Higgins1978), Tanaka (Reference Tanaka1983), MacKay & Saffman (Reference MacKay and Saffman1986)). Saffman’s Hamiltonian approach for periodic waves in deep water was later generalized by Zufiria & Saffman (Reference Zufiria and Saffman1986) to include solitary waves on water of finite depth. Crucially for our purpose, the whole argument remains valid for any canonical Hamiltonian system with the aforementioned symmetries.
The aim of the present paper is to show that Saffman’s result can be further generalized to the extent that symmetry under reflection of the wave profile is not necessary: any translationally symmetric travelling wave solution to a canonical Hamiltonian system exhibits superharmonic exchange of stability when energy is stationary with respect to wave speed. Notice that, in the present analysis, it is assumed that the only degeneracy of the system is the one associated with translational symmetry. Mathematically, this means that the geometric multiplicity of the zero eigenvalue is always unity. This working hypothesis is the same used in the analysis of Saffman (Reference Saffman1985). However, while in Saffman (Reference Saffman1985) the quadruple multiplicity of the zero eigenvalue is obtained by direct evaluation of the generalized eigenvectors (see also Zufiria & Saffman (Reference Zufiria and Saffman1986)), our result relies on the parity of the characteristic polynomial of the matrix associated with the linearized equation for the growth of infinitesimal perturbations. This second approach has the advantage of not requiring the assumption of reflectional symmetry
 $\boldsymbol{A}=\boldsymbol{A}^{\ast }$
, therefore allowing the generalization of Saffman’s result to asymmetric waves.
In the context of fluid dynamics, this result applies to the superharmonic instability of reflectionally asymmetric water wave profiles (Zufiria Reference Zufiria1987), waves in multilayered fluids (Constantin & Ivanov Reference Constantin and Ivanov2015) and rotational water waves (Constantin & Strauss Reference Constantin and Strauss2006; Constantin Reference Constantin2007; Wahlen Reference Wahlen2007). Indeed, such systems are not, in general, symmetric under reflection of the wave profile. However, they arise in canonical Hamiltonian form and admit translationally symmetric travelling wave solutions. In particular, we expect Tanaka’s result to remain true for water waves with constant vorticity at their local extrema of energy with respect to the wave velocity. Indeed, in light of the canonical Hamiltonian formulation of water waves with constant vorticity due to Wahlen (Reference Wahlen2007), the present analysis implies that the same conditions for exchange of stability as the irrotational case hold, even for reflectionally asymmetric wave profiles. Reflectionally symmetric water waves with constant vorticity have been observed numerically (see for example Teles Da Silva & Pregrine (Reference Teles Da Silva and Peregrine1988)), and their stability has been examined by Francius & Kharif (Reference Francius and Kharif2017). Limited to such a symmetric case, the occurrence of Tanaka’s instability has been recently demonstrated by Murashige & Choi (Reference Murashige and Choi2019) through numerical experiments.
The present paper is organized as follows. In § 2, we review how a continuous canonical Hamiltonian system can be transformed to an equivalent system in Fourier space by using a canonical change of variables analogous to that introduced by Zakharov (Reference Zakharov1968). In § 3, we follow the linear stability analysis of Saffman (Reference Saffman1985), without, however, imposing reflectional symmetry, and prove that the characteristic polynomial is an even function of the eigenvalue determining the growth rate of perturbations. The eigenvector associated with translational symmetry is also obtained. In § 4, the result of § 3 is used to show that, in the presence of translational symmetry, the algebraic multiplicity of the zero eigenvalue becomes equal or greater than four when energy is stationary with respect to wave speed. Hence, translationally symmetric travelling wave solutions of a canonical Hamiltonian system exchange their stability at the local extrema of energy. In § 5, we discuss the occurrence of Tanaka’s instability in water waves on a linear shear flow. Here, we provide an alternative derivation of the canonical Hamiltonian formulation of water waves with constant vorticity due to Wahlen (Reference Wahlen2007). Then, we show that travelling wave solutions exhibit translational symmetry. Hence, according to the result proved in §§ 3 and 4, the conditions for exchange of stability to occur at the extrema of the energy are fully verified. The generalization of the theory to non-canonical Hamiltonian systems exhibiting travelling wave solutions with translational symmetry is also addressed. Finally, conclusions are drawn in § 6.
2 Preliminaries
We consider a continuous mechanical system described by a Hamiltonian
 $H$
and canonical variables
 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702})$
,
 $$\begin{eqnarray}\unicode[STIX]{x1D701}_{t}=-\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}},\quad \unicode[STIX]{x1D702}_{t}=\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}.\end{eqnarray}$$
Here
 $t$
is the time variable,
 $H=H[\unicode[STIX]{x1D701},\unicode[STIX]{x1D702}]$
a functional of the functions
 $\unicode[STIX]{x1D701}(\boldsymbol{x},t)$
and
 $\unicode[STIX]{x1D702}(\boldsymbol{x},t)$
, with
 $\boldsymbol{x}\in \mathbb{R}^{m}$
and
 $m$
a positive integer, and
 $\unicode[STIX]{x1D6FF}$
denotes functional derivatives. Both the Hamiltonian
 $H$
and the canonical variables
 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702})$
take real values. In the water wave system,
 $\unicode[STIX]{x1D701}$
represents the velocity potential at the water surface and
 $\unicode[STIX]{x1D702}$
the elevation of the wave profile.
The purpose of this section is to obtain a form of system (2.1) in Fourier space that will be useful for the subsequent linear stability analysis. The procedure adopted here to transform the continuous system (2.1) is analogous to that discussed in Zakharov (Reference Zakharov1968), Saffman (Reference Saffman1985) and Zufiria & Saffman (Reference Zufiria and Saffman1986).
Before carrying out the change to the Fourier variables, it is convenient to introduce the following canonical transformation with complex coefficients,
 $$\begin{eqnarray}a=\frac{\unicode[STIX]{x1D702}+\text{i}\unicode[STIX]{x1D701}}{\sqrt{2}},\quad b=\frac{\unicode[STIX]{x1D702}-\text{i}\unicode[STIX]{x1D701}}{\sqrt{2}}.\end{eqnarray}$$
Note that
 $b=a^{\ast }$
, since
 $(\unicode[STIX]{x1D702},\unicode[STIX]{x1D701})$
are real valued. Here
 $\ast$
denotes a complex conjugate. The inverse transformation is
 $$\begin{eqnarray}\unicode[STIX]{x1D702}=\frac{a+b}{\sqrt{2}},\quad \unicode[STIX]{x1D701}=\frac{a-b}{\text{i}\sqrt{2}}.\end{eqnarray}$$
In terms of
 $(a,b)$
system (2.1) reads as
 $$\begin{eqnarray}a_{t}=-\text{i}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}b},\quad b_{t}=\text{i}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}a},\end{eqnarray}$$
with
 $H=H[a,b]$
. Next, we perform the Fourier transform of system (2.4), where the Fourier transform
 ${\mathcal{F}}[\unicode[STIX]{x1D703}]=\hat{\unicode[STIX]{x1D703}}$
of a function
 $\unicode[STIX]{x1D703}=\unicode[STIX]{x1D703}(\boldsymbol{x},t)$
is defined as
 $$\begin{eqnarray}\hat{\unicode[STIX]{x1D703}}(\boldsymbol{k},t)=\frac{1}{(2\unicode[STIX]{x03C0})^{m/2}}\int _{\mathbb{R}^{m}}\unicode[STIX]{x1D703}(\boldsymbol{x},t)\text{e}^{-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}}\,\text{d}\boldsymbol{x},\quad \boldsymbol{k}\in \mathbb{R}^{m}.\end{eqnarray}$$
The inverse Fourier transform is defined accordingly as
 $$\begin{eqnarray}\unicode[STIX]{x1D703}(\boldsymbol{x},t)=\frac{1}{(2\unicode[STIX]{x03C0})^{m/2}}\int _{\mathbb{R}^{m}}\hat{\unicode[STIX]{x1D703}}(\boldsymbol{k},t)\text{e}^{\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}}\,\text{d}\boldsymbol{k}.\end{eqnarray}$$
Using (2.5), one has
 $$\begin{eqnarray}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D703}}=\int _{\mathbb{R}^{m}}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{\unicode[STIX]{x1D703}}}\frac{\unicode[STIX]{x1D6FF}\hat{\unicode[STIX]{x1D703}}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D703}}\,\text{d}\boldsymbol{k}=\frac{1}{(2\unicode[STIX]{x03C0})^{m/2}}\int _{\mathbb{R}^{m}}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{\unicode[STIX]{x1D703}}}\text{e}^{-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}}\,\text{d}\boldsymbol{k}.\end{eqnarray}$$
Hence, system (2.4) transforms to
 $$\begin{eqnarray}\hat{a}_{t}(\boldsymbol{k})=-\text{i}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{b}}(-\boldsymbol{k}),\quad \hat{b}_{t}(\boldsymbol{k})=\text{i}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{a}}(-\boldsymbol{k}).\end{eqnarray}$$
Here, the dependence on the time variable has been omitted to simplify the notation. Next, notice that, from the definition of the Fourier transform, the following relations hold
 $$\begin{eqnarray}\hat{a}(\boldsymbol{k})=\hat{b}^{\ast }(-\boldsymbol{k}),\quad \hat{b}(\boldsymbol{k})=\hat{a}^{\ast }(-\boldsymbol{k}).\end{eqnarray}$$
Therefore, the left-hand side of system (2.8) can be rewritten so that
 $$\begin{eqnarray}\hat{a}_{t}^{\ast }=\text{i}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{a}},\quad \hat{b}_{t}^{\ast }=-\text{i}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{b}}.\end{eqnarray}$$
In this notation, the dependence on the vector
 $\boldsymbol{k}$
has been omitted because it is redundant. The same convention will be used in the rest of the paper. Taking the complex conjugate of (2.10) gives
 $$\begin{eqnarray}\hat{a}_{t}=-\text{i}\left(\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{a}}\right)^{\ast },\quad \hat{b}_{t}=\text{i}\left(\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{b}}\right)^{\ast }.\end{eqnarray}$$
Now consider how equation (2.10) is modified by a Galilean transformation
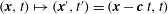 $(\boldsymbol{x},t)\mapsto (\boldsymbol{x}^{\prime },t^{\prime })=(\boldsymbol{x}-\boldsymbol{c}\,t,t)$
to a reference frame moving with constant speed
 $\boldsymbol{c}\in \mathbb{R}^{m}$
. Define
 $s=a(\boldsymbol{x}^{\prime }+\boldsymbol{c}\,t,t)$
. Then
 $$\begin{eqnarray}\hat{a}=\frac{1}{(2\unicode[STIX]{x03C0})^{m/2}}\int _{\mathbb{R}^{m}}a\text{e}^{-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}t}\,\text{d}\boldsymbol{x}=\frac{\text{e}^{-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{c}t}}{(2\unicode[STIX]{x03C0})^{m/2}}\int _{\mathbb{R}^{m}}s\text{e}^{-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{x}^{\prime }}\,\text{d}\boldsymbol{x}^{\prime }=\text{e}^{-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{c}t}{\hat{s}}.\end{eqnarray}$$
In a similar manner, by setting
 $u=b(\boldsymbol{x}^{\prime }+\boldsymbol{c}\,t,t)$
, one has
 $\hat{b}=\text{e}^{-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{c}t}\hat{u}$
. System (2.10) thus becomes
 $$\begin{eqnarray}{\hat{s}}_{t}^{\ast }=-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{c}\,{\hat{s}}^{\ast }+\text{i}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}{\hat{s}}},\quad \hat{u} _{t}^{\ast }=-\text{i}\boldsymbol{k}\boldsymbol{\cdot }\boldsymbol{c}\,\hat{u} ^{\ast }-\text{i}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\hat{u} }.\end{eqnarray}$$
3 Superharmonics and linear stability
In the following we are interested in steady solutions of system (2.13), i.e. travelling wave solutions of system (2.10) with wave speed
 $\boldsymbol{c}$
in the reference frame
 $(\boldsymbol{x},t)$
. Let
 $\unicode[STIX]{x1D706}_{0}$
and
 $k_{0}=2\unicode[STIX]{x03C0}/\unicode[STIX]{x1D706}_{0}$
denote the wavelength and the wavenumber of the steady wave. We consider the linear stability of the steady wave with respect to superharmonic disturbances, i.e. perturbations with wave vector
 $\boldsymbol{k}^{\,j}=jk_{0}\boldsymbol{c}/|\boldsymbol{c}|$
and wavelength
 $\unicode[STIX]{x1D706}^{\,j}=|\,j\,|^{-1}\unicode[STIX]{x1D706}_{0}$
,
 $|\,j\,|\in \mathbb{N}$
. Under these conditions, the energy
 $H$
becomes a discrete sum of energy contributions corresponding to the modes
 $k^{\,j}=jk_{0}$
, while the variables
 $({\hat{s}},\hat{u} )$
are now vectors
 $$\begin{eqnarray}H=H({\hat{s}},\hat{u} ),\quad {\hat{s}}=({\hat{s}}^{1},{\hat{s}}^{2},\ldots )^{\text{T}},\quad \hat{u} =(\hat{u} ^{1},\hat{u} ^{2},\ldots )^{\text{T}},\end{eqnarray}$$
with
 ${\hat{s}}^{\,j}={\hat{s}}(\boldsymbol{k}^{\,j})$
,
 $\hat{u} ^{\,j}=\hat{u} (\boldsymbol{k}^{\,j})$
, and
 $\text{T}$
indicating the transpose. Observe that the energy
 $H$
is now a function of the vectors
 $({\hat{s}},\hat{u} )$
. Hence, functional derivatives are replaced by partial derivatives, and (2.13) becomes
 $$\begin{eqnarray}{\hat{s}}_{t}^{\ast }=-\text{i}\,{\mathcal{I}}\,{\hat{s}}^{\ast }+\text{i}\frac{\unicode[STIX]{x2202}H}{\unicode[STIX]{x2202}{\hat{s}}},\quad \hat{u} _{t}^{\ast }=-\text{i}\,{\mathcal{I}}\,\hat{u} ^{\ast }-\text{i}\frac{\unicode[STIX]{x2202}H}{\unicode[STIX]{x2202}\hat{u} }.\end{eqnarray}$$
Here,
 ${\mathcal{I}}$
is a square diagonal matrix with components
 ${\mathcal{I}}_{\,j}^{i}=cjk_{0}\unicode[STIX]{x1D6FF}_{\,j}^{i}$
where
 $\unicode[STIX]{x1D6FF}_{j}^{i}$
denotes the Kronecker delta, and
 $c=|\boldsymbol{c}|$
.
Let
 $(S,U)$
identify a steady solution of system (3.2). Such solution must satisfy
 $$\begin{eqnarray}0=-\text{i}\,{\mathcal{I}}S^{\ast }+\text{i}\frac{\unicode[STIX]{x2202}H}{\unicode[STIX]{x2202}S},\quad 0=-\text{i}\,{\mathcal{I}}U^{\ast }-\text{i}\frac{\unicode[STIX]{x2202}H}{\unicode[STIX]{x2202}U},\end{eqnarray}$$
where
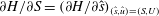 $\unicode[STIX]{x2202}H/\unicode[STIX]{x2202}S=(\unicode[STIX]{x2202}H/\unicode[STIX]{x2202}{\hat{s}})_{({\hat{s}},\hat{u} )=(S,U)}$
and
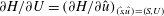 $\unicode[STIX]{x2202}H/\unicode[STIX]{x2202}U=(\unicode[STIX]{x2202}H/\unicode[STIX]{x2202}\hat{u} )_{({\hat{s}},\hat{u} )=(S,U)}$
. This notation will be used throughout the paper. Notice that now the discretized equations (3.2) and (3.3) correspond to (2) and (3) of Saffman (Reference Saffman1985). However, observe that, in contrast with (6) of Saffman (Reference Saffman1985), which implies reflectional symmetry of the wave profile (see the discussion after (15), (30) and (31) in Zufiria & Saffman (Reference Zufiria and Saffman1986) on this point), such symmetry is not assumed here. In practice, the absence of reflectional symmetry makes the Jacobian matrix
 $\unicode[STIX]{x1D645}$
(to be defined shortly) of the linearized equation for the evolution of perturbations complex valued. For this reason, the proof that the zero eigenvalue has at least quadruple multiplicity requires a different approach based on the parity of the characteristic polynomial associated with
 $\unicode[STIX]{x1D645}$
, which is a property that can be deduced from the Hamiltonian nature of the equations.
Next, consider infinitesimal perturbations
 $(d,f)$
of the equilibrium state
 $(S,U)$
 $$\begin{eqnarray}{\hat{s}}=S+\unicode[STIX]{x1D716}d,\quad \hat{u} =U+\unicode[STIX]{x1D716}f,\end{eqnarray}$$
with
 $\unicode[STIX]{x1D716}$
a small positive real constant. By substituting (3.4) into (3.3) and by linearizing around the equilibrium state with respect to the small parameter
 $\unicode[STIX]{x1D716}$
, one arrives at the system of linear equations
 $$\begin{eqnarray}d_{t}^{\ast }=-\text{i}\,{\mathcal{I}}d^{\ast }+\text{i}\unicode[STIX]{x1D648}f+\text{i}\unicode[STIX]{x1D649}d,\quad f_{t}^{\ast }=-\text{i}\,{\mathcal{I}}f^{\ast }-\text{i}\unicode[STIX]{x1D648}^{\text{T}}d-\text{i}\unicode[STIX]{x1D64B}f,\end{eqnarray}$$
with
 $\unicode[STIX]{x1D648}=\unicode[STIX]{x2202}^{2}H/\unicode[STIX]{x2202}S\unicode[STIX]{x2202}U$
,
 $\unicode[STIX]{x1D649}=\unicode[STIX]{x2202}^{2}H/\unicode[STIX]{x2202}S^{2}$
, and
 $\unicode[STIX]{x1D64B}=\unicode[STIX]{x2202}^{2}H/\unicode[STIX]{x2202}U^{2}$
. Note that the matrices
 $\unicode[STIX]{x1D649}$
and
 $\unicode[STIX]{x1D64B}$
are symmetric. It is convenient to put (3.5) into matrix form. Define the vector
 $$\begin{eqnarray}v=(d,f,d^{\ast },f^{\ast })^{\text{T}},\end{eqnarray}$$
and the matrix
 $$\begin{eqnarray}\unicode[STIX]{x1D645}=\text{i}\left[\begin{array}{@{}cccc@{}}{\mathcal{I}} & 0 & -\unicode[STIX]{x1D649}^{\ast } & -\unicode[STIX]{x1D648}^{\ast }\\ 0 & {\mathcal{I}} & \unicode[STIX]{x1D648}^{\dagger } & \unicode[STIX]{x1D64B}^{\ast }\\ \unicode[STIX]{x1D649} & \unicode[STIX]{x1D648} & -{\mathcal{I}} & 0\\ -\unicode[STIX]{x1D648}^{\text{T}} & -\unicode[STIX]{x1D64B} & 0 & -{\mathcal{I}}\end{array}\right].\end{eqnarray}$$
Here,
 $\unicode[STIX]{x1D648}^{\dagger }$
denotes the Hermitian conjugate of
 $\unicode[STIX]{x1D648}$
. Then, the linearized system (3.5) can be written as
 $$\begin{eqnarray}v_{t}=\unicode[STIX]{x1D645}v.\end{eqnarray}$$
The growth rate of infinitesimal perturbations
 $v$
can thus be determined by solving the eigenvalue problem for the matrix
 $\unicode[STIX]{x1D645}$
.
Owing to the Hamiltonian nature of the original system of equations, equation (2.1), the eigenvalues
 $\unicode[STIX]{x1D70E}$
of the matrix
 $\unicode[STIX]{x1D645}$
come in pairs
 $\pm \unicode[STIX]{x1D70E}$
. If
 $d_{+}^{\,j}=d_{0}^{\,j}\text{e}^{\text{i}\unicode[STIX]{x1D70E}t}$
, with
 $d_{0}^{\,j}=d_{0}(k^{\,j})$
a function of
 $k^{\,j}$
, is a solution, so must be
 $d_{-}^{\,j}=d_{0}^{\,j}\text{e}^{-\text{i}\unicode[STIX]{x1D70E}t}$
. To see this explicitly, consider the following matrix
 $$\begin{eqnarray}\unicode[STIX]{x1D64C}=\left[\begin{array}{@{}cccc@{}}0 & 0 & -\unicode[STIX]{x1D644}_{0} & 0\\ 0 & 0 & 0 & \unicode[STIX]{x1D644}_{0}\\ \unicode[STIX]{x1D644}_{0} & 0 & 0 & 0\\ 0 & -\unicode[STIX]{x1D644}_{0} & 0 & 0\end{array}\right].\end{eqnarray}$$
Here,
 $\unicode[STIX]{x1D644}_{0}$
is the identity matrix with the same dimension as that of
 $\unicode[STIX]{x1D648}$
,
 $\unicode[STIX]{x1D649}$
and
 $\unicode[STIX]{x1D64B}$
. We have
 $\unicode[STIX]{x1D64C}^{2}=-\unicode[STIX]{x1D644}$
, where
 $\unicode[STIX]{x1D644}$
is the identity matrix with the same dimension as that of
 $\unicode[STIX]{x1D64C}$
, and
 $\unicode[STIX]{x1D64C}^{\text{T}}=-\unicode[STIX]{x1D64C}$
. Using the fact that the matrices
 $\unicode[STIX]{x1D649}$
and
 $\unicode[STIX]{x1D64B}$
are symmetric, one can verify the following identity
 $$\begin{eqnarray}(\unicode[STIX]{x1D64C}\unicode[STIX]{x1D645})^{\text{T}}=\unicode[STIX]{x1D64C}\unicode[STIX]{x1D645}.\end{eqnarray}$$
It follows that
 $$\begin{eqnarray}\unicode[STIX]{x1D64C}\unicode[STIX]{x1D645}^{\text{T}}\unicode[STIX]{x1D64C}^{\text{T}}=-\unicode[STIX]{x1D645}.\end{eqnarray}$$
Then, the characteristic polynomial
 $p(\unicode[STIX]{x1D70E})$
of the matrix
 $\unicode[STIX]{x1D645}$
satisfies
 $$\begin{eqnarray}p(\unicode[STIX]{x1D70E})=\det (\unicode[STIX]{x1D645}-\unicode[STIX]{x1D70E}\unicode[STIX]{x1D644})=\det (-\unicode[STIX]{x1D64C}\unicode[STIX]{x1D645}^{\text{T}}\unicode[STIX]{x1D64C}^{\text{T}}+\unicode[STIX]{x1D70E}\unicode[STIX]{x1D64C}^{2})=\det (\unicode[STIX]{x1D64C})^{2}\det (\unicode[STIX]{x1D645}^{\text{T}}+\unicode[STIX]{x1D70E}\unicode[STIX]{x1D644})=p(-\unicode[STIX]{x1D70E}).\end{eqnarray}$$
We have thus shown that the characteristic polynomial is an even function of
 $\unicode[STIX]{x1D70E}$
. This result implies that eigenvalues come in pairs
 $\pm \unicode[STIX]{x1D70E}$
, and that any zero eigenvalue
 $\unicode[STIX]{x1D70E}=0$
must have even algebraic multiplicity equal or greater than two.
Here
 $\unicode[STIX]{x1D70E}=0$
is an eigenvalue of the matrix
 $\unicode[STIX]{x1D645}$
. Indeed, by hypothesis, solutions of system (2.1) are invariant under translations. Steady solutions of system (3.8) are therefore not unique, and the kernel of the matrix
 $\unicode[STIX]{x1D645}$
must be non-empty. This implies the existence of an eigenvector
 $\unicode[STIX]{x1D6FC}$
with eigenvalue
 $\unicode[STIX]{x1D70E}=0$
. Notice that it is assumed here that the eigenvector
 $\unicode[STIX]{x1D6FC}$
associated with invariance under translation is the only degeneracy of the matrix
 $\unicode[STIX]{x1D645}$
. The eigenvector
 $\unicode[STIX]{x1D6FC}$
can be evaluated by observing that if
 $S^{\,j}=S(\,jk_{0})$
is a steady solution, then so must be
 $S_{\unicode[STIX]{x1D709}}^{\,j}=\text{e}^{\text{i}j\unicode[STIX]{x1D709}}S^{\,j}$
for any choice of the displacement
 $\unicode[STIX]{x1D709}\in \mathbb{R}$
. Then, the eigenvector
 $\unicode[STIX]{x1D6FC}$
will be the infinitesimal generator of the Lie group associated with the translation of solutions
 $$\begin{eqnarray}\unicode[STIX]{x1D6FC}=-\left[\begin{array}{@{}c@{}}\left({\displaystyle \frac{\text{d}S_{\unicode[STIX]{x1D709}}}{\text{d}\unicode[STIX]{x1D709}}}\right)_{\unicode[STIX]{x1D709}=0}\\ \left({\displaystyle \frac{\text{d}U_{\unicode[STIX]{x1D709}}}{\text{d}\unicode[STIX]{x1D709}}}\right)_{\unicode[STIX]{x1D709}=0}\\ \left({\displaystyle \frac{\text{d}S_{\unicode[STIX]{x1D709}}^{\ast }}{\text{d}\unicode[STIX]{x1D709}}}\right)_{\unicode[STIX]{x1D709}=0}\\ \left({\displaystyle \frac{\text{d}U_{\unicode[STIX]{x1D709}}^{\ast }}{\text{d}\unicode[STIX]{x1D709}}}\right)_{\unicode[STIX]{x1D709}=0}\end{array}\right]=\frac{\text{i}}{ck_{0}}\left[\begin{array}{@{}c@{}}-{\mathcal{I}}S\\ -{\mathcal{I}}U\\ {\mathcal{I}}S^{\ast }\\ {\mathcal{I}}U^{\ast }\end{array}\right].\end{eqnarray}$$
Here we used the fact that translating
 $U(\boldsymbol{k})$
is tantamount to translating
 $S^{\ast }(-\boldsymbol{k})$
. The minus sign in the definition of
 $\unicode[STIX]{x1D6FC}$
was put in for later convenience.
4 Exchange of stability
The purpose of the present section is to obtain the conditions under which exchange of stability occurs. Mathematically, this amounts to determining the values of the wave speed
 $c$
at which the algebraic multiplicity of the eigenvalue
 $\unicode[STIX]{x1D70E}=0$
is greater than two. In particular, it will be shown that this occurs at stationary points of the energy,
 $\text{d}H/\text{d}c=0$
, and that, at such points, the algebraic multiplicity is equal or greater than four, while the geometric multiplicity is unity. In contrast with Saffman (Reference Saffman1985), symmetry under reflection of the wave profile is not used in the analysis, thereby generalizing his result.
First, observe that, from (3.3), the variables
 $(S,U)$
, and consequently the Hamiltonian
 $H(S,U)$
can be regarded as functions of wave speed
 $c$
. The energy
 $H$
is stationary with respect to wave speed
 $c$
when
 $$\begin{eqnarray}\frac{\text{d}H}{\text{d}c}=\frac{\unicode[STIX]{x2202}H}{\unicode[STIX]{x2202}S^{\,j}}\frac{\text{d}S^{\,j}}{\text{d}c}+\frac{\unicode[STIX]{x2202}H}{\unicode[STIX]{x2202}U^{\,j}}\frac{\text{d}U^{\,j}}{\text{d}c}=0.\end{eqnarray}$$
In light of (3.3), equation (4.1) can be written as
 $$\begin{eqnarray}\frac{\text{d}H}{\text{d}c}=\left(\frac{\text{d}S}{\text{d}c},{\mathcal{I}}S\right)-\left(\frac{\text{d}U}{\text{d}c},{\mathcal{I}}U\right)=0,\end{eqnarray}$$
where
 $(x,y)=x\cdot y^{\ast }$
denotes the inner product of two complex vectors
 $x$
and
 $y$
.
At this point it is useful to make some considerations on the simplification of (4.2) that occurs if the wave profile is symmetric under reflection. For this purpose it is sufficient to consider the one-dimensional case
 $\unicode[STIX]{x1D702}=\unicode[STIX]{x1D702}(x,t)$
, with
 $x\in \mathbb{R}$
. Symmetry under reflection translates into the condition that
 $$\begin{eqnarray}\unicode[STIX]{x1D702}(x^{\prime },t)=\unicode[STIX]{x1D702}(-x^{\prime },t),\quad x^{\prime }=x-ct.\end{eqnarray}$$
On the other hand, recall that
 $\sqrt{2}\,\unicode[STIX]{x1D702}=s+s^{\ast }$
. In the superharmonic setting, the variable
 $s$
can be expanded into a Fourier series as
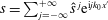 $s=\sum _{j=-\infty }^{+\infty }{\hat{s}}^{\,j}\text{e}^{\text{i}jk_{0}x^{\prime }}$
. Hence, equation (4.3) implies that
 $$\begin{eqnarray}0=\mathop{\sum }_{j=-\infty }^{+\infty }({\hat{s}}^{\,j}-{\hat{s}}^{\,j\ast })\sin (\,jk_{0}x^{\prime }).\end{eqnarray}$$
This condition can be satisfied by demanding that
 ${\hat{s}}={\hat{s}}^{\ast }$
. In such a case,
 $\hat{u} ^{-j}={\hat{s}}^{\,j\ast }={\hat{s}}^{\,j}$
. Furthermore, the Hamiltonian of the water wave system, which can be written as a function of
 ${\hat{s}}$
and
 ${\hat{s}}^{\ast }$
, is endowed with the symmetry
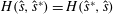 $H({\hat{s}},{\hat{s}}^{\ast })=H({\hat{s}}^{\ast },{\hat{s}})$
. Therefore, if the wave profile is assumed to be symmetric under reflection, equation (4.2) reduces to the requirement
 $$\begin{eqnarray}0=2\frac{\text{d}S}{\text{d}c}\boldsymbol{\cdot }{\mathcal{I}}S.\end{eqnarray}$$
This is the scenario examined by Saffman (Reference Saffman1985).
We now return to the problem without reflectional symmetry. By differentiating the equilibrium system (3.3) with respect to wave velocity
 $c$
, the following relationships can be derived
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}\displaystyle {\mathcal{I}}\frac{\text{d}S^{\ast }}{\text{d}c}-\unicode[STIX]{x1D648}\frac{\text{d}U}{\text{d}c}-\unicode[STIX]{x1D649}\frac{\text{d}S}{\text{d}c}=-c^{-1}{\mathcal{I}}S^{\ast },\\ \displaystyle {\mathcal{I}}\frac{\text{d}U^{\ast }}{\text{d}c}+\unicode[STIX]{x1D64B}\frac{\text{d}U}{\text{d}c}+\unicode[STIX]{x1D648}^{\text{T}}\frac{\text{d}S}{\text{d}c}=-c^{-1}{\mathcal{I}}U^{\ast }.\end{array}\right\}\end{eqnarray}$$
We further define
 $$\begin{eqnarray}\unicode[STIX]{x1D6FD}=\frac{1}{k_{0}}\left(\frac{\text{d}S}{\text{d}c},\frac{\text{d}U}{\text{d}c},\frac{\text{d}S^{\ast }}{\text{d}c},\frac{\text{d}U^{\ast }}{\text{d}c}\right)^{\text{T}}.\end{eqnarray}$$
Then, system (4.6) has the form
 $$\begin{eqnarray}\unicode[STIX]{x1D645}\unicode[STIX]{x1D6FD}=\unicode[STIX]{x1D6FC},\end{eqnarray}$$
implying
 $$\begin{eqnarray}\unicode[STIX]{x1D645}^{2}\unicode[STIX]{x1D6FD}=0.\end{eqnarray}$$
Hence,
 $\unicode[STIX]{x1D6FD}$
is a generalized eigenvector of rank two associated with the eigenvalue
 $\unicode[STIX]{x1D70E}=0$
. This is consistent with the fact that the algebraic multiplicity of
 $\unicode[STIX]{x1D70E}=0$
is at least two. Exchange of stability occurs when the eigenvalue
 $\unicode[STIX]{x1D70E}=0$
has algebraic multiplicity greater or equal to four, while the geometric multiplicity of the associated eigenvector remains unity. Since it has been shown that the characteristic polynomial of the matrix
 $\unicode[STIX]{x1D645}$
is even, it is sufficient to determine the values of
 $c$
such that the algebraic multiplicity of
 $\unicode[STIX]{x1D70E}=0$
is three to obtain exchange of stability.
Let
 $\unicode[STIX]{x1D645}^{\dagger }$
denote the Hermitian conjugate of
 $\unicode[STIX]{x1D645}$
, and
 $\text{ker}\,\unicode[STIX]{x1D645}^{\dagger }$
the kernel of the operator
 $\unicode[STIX]{x1D645}^{\dagger }$
. We wish to show that, if a vector
 $f$
is orthogonal to the elements of
 $\text{ker}\,\unicode[STIX]{x1D645}^{\dagger }$
, i.e.
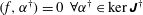 $(f,\unicode[STIX]{x1D6FC}^{\dagger })=0~\forall \unicode[STIX]{x1D6FC}^{\dagger }\in \text{ker}\,\unicode[STIX]{x1D645}^{\dagger }$
, then
 $f\in \text{Im}\,\unicode[STIX]{x1D645}$
, where
 $\text{Im}\,\unicode[STIX]{x1D645}$
denotes the image of the operator
 $\unicode[STIX]{x1D645}$
. A vector
 $f$
belongs to
 $\text{Im}\,\unicode[STIX]{x1D645}$
if there exists a vector
 $\unicode[STIX]{x1D6FE}$
such that
 $f=\unicode[STIX]{x1D645}\unicode[STIX]{x1D6FE}$
. Suppose that
 $f\notin \text{Im}\,\unicode[STIX]{x1D645}$
. Then
 $f$
can be decomposed as
 $f=\unicode[STIX]{x1D645}\unicode[STIX]{x1D6FE}+\unicode[STIX]{x1D716}$
, with
 $\unicode[STIX]{x1D716}\bot \text{Im}\,\unicode[STIX]{x1D645}$
. Since
 $f$
is orthogonal to
 $\text{ker}\,\unicode[STIX]{x1D645}^{\dagger }$
, one has
 $$\begin{eqnarray}(f,\unicode[STIX]{x1D6FC}^{\dagger })=(\unicode[STIX]{x1D645}\unicode[STIX]{x1D6FE}+\unicode[STIX]{x1D716},\unicode[STIX]{x1D6FC}^{\dagger })=(\unicode[STIX]{x1D716},\unicode[STIX]{x1D6FC}^{\dagger })=0,\quad \forall \unicode[STIX]{x1D6FC}^{\dagger }\in \text{ker}\,\unicode[STIX]{x1D645}^{\dagger }.\end{eqnarray}$$
Hence,
 $\unicode[STIX]{x1D716}\notin \text{ker}\,\unicode[STIX]{x1D645}^{\dagger }$
. On the other hand,
 $\unicode[STIX]{x1D716}$
is, by construction, orthogonal to
 $\text{Im}\,\unicode[STIX]{x1D645}$
, implying that
 $$\begin{eqnarray}(\unicode[STIX]{x1D716},\unicode[STIX]{x1D645}\unicode[STIX]{x1D6FF})=(\unicode[STIX]{x1D645}^{\dagger }\unicode[STIX]{x1D716},\unicode[STIX]{x1D6FF})=0,\quad \forall \unicode[STIX]{x1D6FF}.\end{eqnarray}$$
But then
 $\unicode[STIX]{x1D716}\in \text{ker}\,\unicode[STIX]{x1D645}^{\dagger }$
. Therefore
 $\unicode[STIX]{x1D716}=0$
and
 $f\in \text{Im}\,\unicode[STIX]{x1D645}$
. By the identification
 $f=\unicode[STIX]{x1D6FD}$
, it follows that the sufficient condition for
 $\unicode[STIX]{x1D6FD}$
to belong to the image of
 $\unicode[STIX]{x1D645}$
is that
 $$\begin{eqnarray}(\unicode[STIX]{x1D6FD},\unicode[STIX]{x1D6FC}^{\dagger })=0.\end{eqnarray}$$
If such a condition is satisfied then,
 $\unicode[STIX]{x1D6FD}=\unicode[STIX]{x1D645}\unicode[STIX]{x1D6FE}$
for some vector
 $\unicode[STIX]{x1D6FE}$
, implying that
 $\unicode[STIX]{x1D6FE}$
is a generalized eigenvector of rank three associated with the eigenvalue
 $\unicode[STIX]{x1D70E}=0$
. Due to the parity of the characteristic polynomial, satisfying (4.12) is thus enough to prove that the zero eigenvalue has algebraic multiplicity equal or greater than four and geometric multiplicity of one.
Here
 $\unicode[STIX]{x1D6FC}^{\dagger }$
can be evaluated explicitly by demanding that
 $\unicode[STIX]{x1D645}^{\dagger }\unicode[STIX]{x1D6FC}^{\dagger }=0$
and using the condition
 $\unicode[STIX]{x1D645}\unicode[STIX]{x1D6FC}=0$
. The expression of
 $\unicode[STIX]{x1D6FC}^{\dagger }$
is
 $$\begin{eqnarray}\unicode[STIX]{x1D6FC}^{\dagger }=k_{0}(-{\mathcal{I}}S,{\mathcal{I}}U,-{\mathcal{I}}S^{\ast },{\mathcal{I}}U^{\ast })^{\text{T}}.\end{eqnarray}$$
Equation (4.12) thus becomes
 $$\begin{eqnarray}(\unicode[STIX]{x1D6FD},\unicode[STIX]{x1D6FC}^{\dagger })=-\left(\frac{\text{d}S}{\text{d}c},{\mathcal{I}}S\right)+\left(\frac{\text{d}U}{\text{d}c},{\mathcal{I}}U\right)-\left(\frac{\text{d}S^{\ast }}{\text{d}c},{\mathcal{I}}S^{\ast }\right)+\left(\frac{\text{d}U^{\ast }}{\text{d}c},{\mathcal{I}}U^{\ast }\right)=0.\end{eqnarray}$$
On the other hand, recalling the expression of
 $\text{d}H/\text{d}c$
, equation (4.2), it follows that
 $$\begin{eqnarray}(\unicode[STIX]{x1D6FD},\unicode[STIX]{x1D6FC}^{\dagger })=-2\text{Re}\left(\frac{\text{d}H}{\text{d}c}\right)=-2\frac{\text{d}H}{\text{d}c}=0.\end{eqnarray}$$
Hence, exchange of stability occurs at stationary points of the energy.
5 Generalizations and examples: water waves with constant vorticity
The analysis of the previous sections can be slightly generalized. First, observe that the number of canonical pairs
 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702})$
does not need to be one: by setting
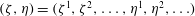 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702})=(\unicode[STIX]{x1D701}^{1},\unicode[STIX]{x1D701}^{2},\ldots ,\unicode[STIX]{x1D702}^{1},\unicode[STIX]{x1D702}^{2},\ldots )$
, with
 $\unicode[STIX]{x1D701}^{i}(\boldsymbol{x},t)$
and
 $\unicode[STIX]{x1D702}^{i}(\boldsymbol{x},t)$
the
 $i$
th canonical pair, one can verify that the results of the previous sections remain unchanged. In particular, they apply to non-canonical Hamiltonian systems that can be cast in Darboux form, which is a canonical Hamiltonian form on a submanifold defined by the constraints (Casimir invariants) that characterize the non-canonical Hamiltonian structure. More precisely, consider a non-canonical Hamiltonian system
 $$\begin{eqnarray}\boldsymbol{z}_{t}={\mathcal{J}}\unicode[STIX]{x1D6FF}_{\boldsymbol{z}}H,\end{eqnarray}$$
where
 $\boldsymbol{z}$
takes values in a domain
 $\unicode[STIX]{x1D6FA}\subset \mathbb{R}^{n}$
and is an element of a Hilbert space
 $X$
defining phase space,
 $H[\boldsymbol{z}]$
a smooth function in
 $X$
representing the Hamiltonian of the system,
 $\unicode[STIX]{x1D6FF}_{\boldsymbol{z}}$
the functional derivative with respect to
 $\boldsymbol{z}$
, and
 ${\mathcal{J}}$
the Poisson operator. Here, the Poisson operator is defined by the properties of the associated Poisson bracket, the bilinear form
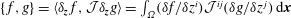 $\{\,f,g\}=\langle \unicode[STIX]{x1D6FF}_{\boldsymbol{z}}\,f,{\mathcal{J}}\unicode[STIX]{x1D6FF}_{\boldsymbol{z}}g\rangle =\int _{\unicode[STIX]{x1D6FA}}(\unicode[STIX]{x1D6FF}f/\unicode[STIX]{x1D6FF}z^{i}){\mathcal{J}}^{ij}(\unicode[STIX]{x1D6FF}g/\unicode[STIX]{x1D6FF}z^{\,j})\,\text{d}\boldsymbol{x}$
, which satisfies antisymmetry
 $\{\,f,g\}=-\{g,f\}$
and Jacobi identity
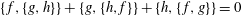 $\{\,f,\{g,h\}\}+\{g,\{h,f\}\}+\{h,\{\,f,g\}\}=0$
, with
 $f$
,
 $g$
and
 $h$
arbitrary smooth functionals on
 $X$
. Suppose that there exists a change of variables
 $\boldsymbol{z}\mapsto (\unicode[STIX]{x1D701},\unicode[STIX]{x1D702},C)$
such that the variables
 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702})$
are canonically conjugated, i.e.
 $\unicode[STIX]{x1D701}_{t}^{i}=-\unicode[STIX]{x1D6FF}H/\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}^{i}$
and
 $\unicode[STIX]{x1D702}_{t}^{i}=\unicode[STIX]{x1D6FF}H/\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}^{i}$
, and the variables
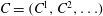 $C=(C^{1},C^{2},\ldots )$
are constants of motion (Casimir invariants) due to the property that
 $\{\,f,C^{\,j}\}=0$
for all smooth functionals
 $f$
, which implies
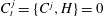 $C_{t}^{\,j}=\{C^{\,j},H\}=0$
. Then, the transformed Poisson operator
 $\mathfrak{J}$
is in Darboux form, meaning that it acts as a degenerate symplectic matrix, with the degeneracy represented by the existence of Casimir invariants
 $C$
 $$\begin{eqnarray}\mathfrak{J}=\left[\begin{array}{@{}ccc@{}}0_{m} & -\unicode[STIX]{x1D644}_{m} & 0\\ \unicode[STIX]{x1D644}_{m} & 0_{m} & 0\\ 0 & 0 & 0_{q}\end{array}\right].\end{eqnarray}$$
Here,
 $0_{m}$
and
 $\unicode[STIX]{x1D644}_{m}$
are the
 $m$
-dimensional null and identity matrix, respectively, with
 $m$
the number of canonical pairs, and
 $0_{q}$
the
 $q$
-dimensional null matrix, with
 $q$
the number of Casimir invariants. If one is able to find such a change of variables, the stability analysis of the present paper applies. It is worth observing that, however, the existence of the Darboux form for the Poisson operator is guaranteed only locally and for finite dimensional systems (Darboux theorem, see de León (Reference de León1989)).
5.1 Water waves with constant vorticity
As an application of the theory to fluid dynamics, we now consider the superharmonic instability of gravity-capillary waves over a linear shear flow. The problem can be studied in two dimensions
 $(x,y)$
, with the horizontal axis
 $x$
aligned with phase speed,
 $\boldsymbol{c}=c\unicode[STIX]{x2202}_{x}$
, and the variable
 $y$
representing the spatial coordinate along the upward vertical axis. In this notation,
 $\unicode[STIX]{x2202}_{x}$
and
 $\unicode[STIX]{x2202}_{y}$
represent the unit tangent vectors along the
 $x$
-axis and
 $y$
-axis, respectively. We assume the system to be periodic in the
 $x$
-direction with period
 $L$
. The domain occupied by the fluid is
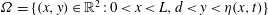 $\unicode[STIX]{x1D6FA}=\{(x,y)\in \mathbb{R}^{2}:0<x<L,d<y<\unicode[STIX]{x1D702}(x,t)\}$
with boundary
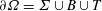 $\unicode[STIX]{x2202}\unicode[STIX]{x1D6FA}=\unicode[STIX]{x1D6F4}\cup B\cup T$
, where
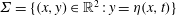 $\unicode[STIX]{x1D6F4}=\{(x,y)\in \mathbb{R}^{2}:y=\unicode[STIX]{x1D702}(x,t)\}$
is the fluid surface,
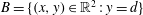 $B=\{(x,y)\in \mathbb{R}^{2}:y=d\}$
the fluid bottom at constant depth
 $d\leqslant 0$
,
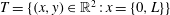 $T=\{(x,y)\in \mathbb{R}^{2}:x=\{0,L\}\}$
the vertical boundary, and
 $\unicode[STIX]{x1D702}(x,t)$
the elevation of the water surface at
 $(x,t)$
. We further demand that the fluid velocity
 $\boldsymbol{v}=(v_{x},v_{y})$
is given by
 $$\begin{eqnarray}\boldsymbol{v}=\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}-\unicode[STIX]{x1D714}y\unicode[STIX]{x2202}_{x}.\end{eqnarray}$$
Here,
 $\unicode[STIX]{x1D714}\in \mathbb{R}$
is a constant representing the vorticity of the system
 $$\begin{eqnarray}\unicode[STIX]{x1D714}=\frac{\unicode[STIX]{x2202}v_{y}}{\unicode[STIX]{x2202}x}-\frac{\unicode[STIX]{x2202}v_{x}}{\unicode[STIX]{x2202}y},\end{eqnarray}$$
and the function
 $\unicode[STIX]{x1D719}$
is the velocity potential. Then, it can be shown that the two-dimensional ideal Euler equations at constant fluid density reduce to the following system of partial differential equations for the variable
 $\unicode[STIX]{x1D719}$
 $$\begin{eqnarray}\unicode[STIX]{x1D719}_{t}=f-\unicode[STIX]{x1D714}\unicode[STIX]{x1D713}-\frac{|\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}|^{2}}{2}+\unicode[STIX]{x1D714}y\unicode[STIX]{x1D719}_{x}-P-gy,\quad \unicode[STIX]{x0394}\unicode[STIX]{x1D719}=0\quad \text{in}~\unicode[STIX]{x1D6FA}.\end{eqnarray}$$
Here,
 $f=f(t)$
is an arbitrary function of time
 $t$
,
 $P$
the pressure,
 $g$
the gravitational constant, and the function
 $\unicode[STIX]{x1D713}$
the harmonic conjugate of
 $\unicode[STIX]{x1D719}$
such that
 $\unicode[STIX]{x1D719}_{x}=\unicode[STIX]{x1D713}_{y}$
and
 $\unicode[STIX]{x1D719}_{y}=-\unicode[STIX]{x1D713}_{x}$
(a lower index indicates derivation; this notation is used in the rest of the paper). The function
 $\unicode[STIX]{x1D719}$
is harmonic as a direct consequence of the continuity equation, which implies that the fluid velocity must be divergence free in a regime of constant fluid density. System (5.5) must be further supplied with boundary conditions at the top surface
 $\unicode[STIX]{x1D6F4}$
, the bottom
 $B$
, and the vertical boundary
 $T$
. At the vertical boundary
 $T$
, we impose periodic boundary conditions for the velocity,
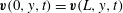 $\boldsymbol{v}(0,y,t)=\boldsymbol{v}(L,y,t)$
. At the bottom
 $B$
, we require the Neumann boundary condition
 $\unicode[STIX]{x1D719}_{y}=0$
. Finally, at the water surface
 $\unicode[STIX]{x1D6F4}$
we have
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D719}_{t}=f-\unicode[STIX]{x1D714}\unicode[STIX]{x1D713}-\frac{|\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}|^{2}}{2}+\unicode[STIX]{x1D714}y\unicode[STIX]{x1D719}_{x}-gy+\unicode[STIX]{x1D6FC}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}x}\left(\frac{\unicode[STIX]{x1D702}_{x}}{\sqrt{1+\unicode[STIX]{x1D702}_{x}^{2}}}\right), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \unicode[STIX]{x1D702}_{t}=\unicode[STIX]{x1D719}_{y}-\unicode[STIX]{x1D719}_{x}\unicode[STIX]{x1D702}_{x}+\unicode[STIX]{x1D714}y\unicode[STIX]{x1D702}_{x}. & \displaystyle\end{eqnarray}$$
 $P$
was reabsorbed in the definition of
 $f$
, since, at the water surface,
 $P$
equals the constant atmospheric pressure of the overlying air. The last term in (5.6a
) represents surface tension, with
 $\unicode[STIX]{x1D6FC}\in \mathbb{R}$
a constant. Equation (5.6b
) can be deduced by the fact that the quantity
 $\unicode[STIX]{x1D702}(x,t)-y$
must be preserved along the flow
 $\boldsymbol{v}$
. Observe that a solution
 $(\unicode[STIX]{x1D719},\unicode[STIX]{x1D702})$
of system (5.6) at the surface
 $\unicode[STIX]{x1D6F4}$
determines
 $\unicode[STIX]{x1D719}$
in the whole
 $\unicode[STIX]{x1D6FA}$
. Indeed, the value of
 $\unicode[STIX]{x1D719}$
in the interior domain can be obtained as the unique solution of the second equation of system (5.5) by imposition of the computed dynamic boundary conditions on
 $\unicode[STIX]{x2202}\unicode[STIX]{x1D6FA}$
. In what follows, we therefore restrict our attention to system (5.6), which represents water waves with constant vorticity. It is now convenient to introduce the following notation
 $$\begin{eqnarray}\unicode[STIX]{x1D717}=\unicode[STIX]{x1D719}|_{y=\unicode[STIX]{x1D702}},\quad \unicode[STIX]{x1D712}=\unicode[STIX]{x1D713}|_{y=\unicode[STIX]{x1D702}}.\end{eqnarray}$$
For exchange of stability to occur at the extrema of energy with respect to wave speed (provided that such extrema exist), it is sufficient to show that system (5.6) has a canonical Hamiltonian form with translationally symmetric travelling wave solutions. Wahlen (Reference Wahlen2007) has obtained the canonical Hamiltonian formulation of two-dimensional periodic gravity-capillary waves with constant vorticity in water of finite depth by finding the change of variables
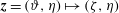 $\boldsymbol{z}=(\unicode[STIX]{x1D717},\unicode[STIX]{x1D702})\mapsto (\unicode[STIX]{x1D701},\unicode[STIX]{x1D702})$
that transforms the non-canonical Poisson operator
 ${\mathcal{J}}$
 $$\begin{eqnarray}{\mathcal{J}}=\left[\begin{array}{@{}cc@{}}\displaystyle \unicode[STIX]{x1D714}\int & -1\\ 1 & 0\end{array}\right],\end{eqnarray}$$
of the system into the canonical symplectic matrix
 $$\begin{eqnarray}\mathfrak{J}=\left[\begin{array}{@{}cc@{}}0 & -1\\ 1 & 0\end{array}\right].\end{eqnarray}$$
We refer the reader to Wahlen (Reference Wahlen2007) for the precise definition of the integral operator
 $\unicode[STIX]{x1D714}\int$
appearing in the non-canonical Poisson operator (5.8). Note that, as in the case of irrotational water waves, there is only a single canonical pair
 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702})=(\unicode[STIX]{x1D701}^{1},\unicode[STIX]{x1D702}^{1})$
. Hence, when written in terms of the canonical variables, equation (5.1) reduces to the canonical form (2.1)
 $$\begin{eqnarray}\left[\begin{array}{@{}c@{}}\unicode[STIX]{x1D701}_{t}\\ \unicode[STIX]{x1D702}_{t}\end{array}\right]=\mathfrak{J}\left[\begin{array}{@{}c@{}}\displaystyle \frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}\\ \displaystyle \frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}\end{array}\right]=\left[\begin{array}{@{}c@{}}\displaystyle -\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}\\ \displaystyle \frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}\end{array}\right].\end{eqnarray}$$
In the remaining part of this section, we first provide an alternative derivation of the canonical Hamiltonian formulation of water waves with constant vorticity due to Wahlen (Reference Wahlen2007). In Wahlen (Reference Wahlen2007) the form of the canonical momentum
 $\unicode[STIX]{x1D701}$
is assumed, and it is shown that, with this choice, the non-canonical Poisson operator transforms to the canonical symplectic matrix. Here, we solve Hamilton’s canonical equations for the unknown canonical momentum
 $\unicode[STIX]{x1D701}$
, and verify the obtained result by directly taking the variation of the Hamiltonian to produce the equations of motion. Then, we show that, if travelling wave solutions exist, they possess translational symmetry. Hence, according to the result proved in §§ 3 and 4, the conditions for exchange of stability to occur at the extrema of the energy are fully verified. Note that there is no need to assume, at any point of the analysis, reflectional symmetry of the wave profile. We limit our attention to gravity-capillary waves in deep water, i.e.
 $d\rightarrow -\infty$
(the calculations remain unchanged for other values of
 $d$
).
5.2 Derivation of the canonical momentum
The purpose of this subsection is to derive the canonical momentum
 $\unicode[STIX]{x1D701}$
conjugated to the elevation
 $\unicode[STIX]{x1D702}$
. If
 $\unicode[STIX]{x1D701}$
and
 $\unicode[STIX]{x1D702}$
are canonically conjugated variables, the evolution of
 $\unicode[STIX]{x1D702}$
must be given by the gradient of the Hamiltonian
 $H[\unicode[STIX]{x1D701},\unicode[STIX]{x1D702}]$
with respect to
 $\unicode[STIX]{x1D701}$
. In the following calculations it is convenient to adopt the notation
 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702}^{\prime })$
, with
 $\unicode[STIX]{x1D702}^{\prime }=\unicode[STIX]{x1D702}$
, to avoid ambiguity in the differentiation of the Hamiltonian. By application of the chain rule for the change of variables
 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702}^{\prime })\mapsto (\unicode[STIX]{x1D717},\unicode[STIX]{x1D702})$
, we thus have
 $$\begin{eqnarray}\unicode[STIX]{x1D702}_{t}^{\prime }=\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}=\int \left(\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}+\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}\right)\,\text{d}s=\int \frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}\,\text{d}s=\int \unicode[STIX]{x1D702}_{t}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}\,\text{d}s.\end{eqnarray}$$
Here, integration with respect to the variable
 $s$
is performed on the interval
 $[0,L]$
,
 $\unicode[STIX]{x1D702}=\unicode[STIX]{x1D702}(s,t)$
,
 $\unicode[STIX]{x1D717}=\unicode[STIX]{x1D717}(s,t)$
and
 $\unicode[STIX]{x1D701}=\unicode[STIX]{x1D701}(x,t)$
. In the last passage, we used the fact that, from (5.8),
 $\unicode[STIX]{x1D702}_{t}=\unicode[STIX]{x1D6FF}H/\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}$
. Equation (5.11) thus implies that
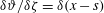 $\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}/\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}=\unicode[STIX]{x1D6FF}(x-s)$
. Therefore,
 $$\begin{eqnarray}\unicode[STIX]{x1D717}=\unicode[STIX]{x1D701}+\unicode[STIX]{x1D70E}[\unicode[STIX]{x1D702}^{\prime }],\end{eqnarray}$$
where
 $\unicode[STIX]{x1D70E}[\unicode[STIX]{x1D702}^{\prime }]$
is an integro-differential operator acting on
 $\unicode[STIX]{x1D702}^{\prime }$
to be determined. The operator
 $\unicode[STIX]{x1D70E}$
can be obtained by requiring that the evolution of
 $\unicode[STIX]{x1D701}$
is minus the gradient of the Hamiltonian with respect to
 $\unicode[STIX]{x1D702}^{\prime }$
. Applying the chain rule again
 $$\begin{eqnarray}\unicode[STIX]{x1D701}_{t}=-\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}^{\prime }}=-\int \left(\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}^{\prime }}+\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}^{\prime }}\right)\,\text{d}s=-\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}-\int \left(\unicode[STIX]{x1D702}_{t}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D70E}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}^{\prime }}\right)\,\text{d}s.\end{eqnarray}$$
In the last passage, we used the fact that
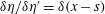 $\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}/\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}^{\prime }=\unicode[STIX]{x1D6FF}(x-s)$
and
 $\unicode[STIX]{x1D702}_{t}=\unicode[STIX]{x1D6FF}H/\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}$
. On the other hand, recalling (5.8), we have
 $$\begin{eqnarray}\unicode[STIX]{x1D701}_{t}=\unicode[STIX]{x1D717}_{t}-\unicode[STIX]{x1D70E}_{t}=-\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}+\unicode[STIX]{x1D714}\int \frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}}-\unicode[STIX]{x1D70E}_{t}=-\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}+\unicode[STIX]{x1D714}\int \unicode[STIX]{x1D702}_{t}-\unicode[STIX]{x1D70E}_{t}.\end{eqnarray}$$
Here,
 $\unicode[STIX]{x1D714}\int =\unicode[STIX]{x1D714}\int _{0}^{x}\,\text{d}s$
is the integral operator introduced in (5.8). Furthermore, setting
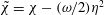 $\tilde{\unicode[STIX]{x1D712}}=\unicode[STIX]{x1D712}-(\unicode[STIX]{x1D714}/2)\unicode[STIX]{x1D702}^{2}$
, observe that
 $$\begin{eqnarray}\displaystyle -\tilde{\unicode[STIX]{x1D712}}_{x}=\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}x}\left(\frac{\unicode[STIX]{x1D714}}{2}\unicode[STIX]{x1D702}^{2}-\unicode[STIX]{x1D712}\right) & = & \displaystyle \unicode[STIX]{x1D714}\unicode[STIX]{x1D702}\unicode[STIX]{x1D702}_{x}-\unicode[STIX]{x1D713}_{x}(x,\unicode[STIX]{x1D702},t)-\unicode[STIX]{x1D713}_{y}(x,\unicode[STIX]{x1D702},t)\unicode[STIX]{x1D702}_{x}\nonumber\\ \displaystyle & = & \displaystyle \unicode[STIX]{x1D714}\unicode[STIX]{x1D702}\unicode[STIX]{x1D702}_{x}+\unicode[STIX]{x1D719}_{y}(x,\unicode[STIX]{x1D702},t)-\unicode[STIX]{x1D719}_{x}(x,\unicode[STIX]{x1D702},t)\unicode[STIX]{x1D702}_{x}=\unicode[STIX]{x1D702}_{t}.\end{eqnarray}$$
Hence, substituting (5.15) in (5.13) and (5.14), and comparing (5.13) with (5.14), it follows that
 $\unicode[STIX]{x1D70E}$
must satisfy the condition
 $$\begin{eqnarray}\left.\left(\tilde{\unicode[STIX]{x1D712}}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D70E}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}^{\prime }}\right)\right|_{0}^{L}-\int \left(\tilde{\unicode[STIX]{x1D712}}\frac{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D70E}_{s}}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}^{\prime }}\right)\,\text{d}s=-\unicode[STIX]{x1D714}\tilde{\unicode[STIX]{x1D712}}+\unicode[STIX]{x1D714}\tilde{\unicode[STIX]{x1D712}}(0,t)-\unicode[STIX]{x1D70E}_{t}.\end{eqnarray}$$
Here, the left-hand side was obtained using integration by parts. Since
 $\unicode[STIX]{x1D713}$
, and therefore
 $\tilde{\unicode[STIX]{x1D712}}$
, are defined up to an arbitrary function of time, it is convenient to eliminate the time-dependent term
 $\tilde{\unicode[STIX]{x1D712}}(0,t)$
by redefining
 $\tilde{\unicode[STIX]{x1D712}}$
as
 $\tilde{\unicode[STIX]{x1D712}}^{\prime }=\tilde{\unicode[STIX]{x1D712}}-\tilde{\unicode[STIX]{x1D712}}(0,t)$
. Hence, from conservation of total mass
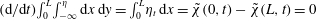 $(\text{d}/\text{d}t)\int _{0}^{L}\int _{-\infty }^{\unicode[STIX]{x1D702}}\,\text{d}x\,\text{d}y=\int _{0}^{L}\unicode[STIX]{x1D702}_{t}\,\text{d}x=\tilde{\unicode[STIX]{x1D712}}(0,t)-\tilde{\unicode[STIX]{x1D712}}(L,t)=0$
, we obtain
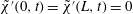 $\tilde{\unicode[STIX]{x1D712}}^{\prime }(0,t)=\tilde{\unicode[STIX]{x1D712}}^{\prime }(L,t)=0$
. Then, one sees that a solution of (5.16) is
 $$\begin{eqnarray}\unicode[STIX]{x1D70E}=\frac{\unicode[STIX]{x1D714}}{2}\int _{0}^{x}\unicode[STIX]{x1D702}(s,t)\,\text{d}s.\end{eqnarray}$$
From (5.12), we conclude that the canonical momentum
 $\unicode[STIX]{x1D701}$
is given by
 $$\begin{eqnarray}\unicode[STIX]{x1D701}=\unicode[STIX]{x1D717}-\frac{\unicode[STIX]{x1D714}}{2}\int _{0}^{x}\unicode[STIX]{x1D702}(s,t)\,\text{d}s.\end{eqnarray}$$
5.3 Variation of the Hamiltonian
The Hamiltonian of the system, representing total kinetic plus potential energy, can be written as
 $$\begin{eqnarray}H[\unicode[STIX]{x1D701},\unicode[STIX]{x1D702}]=\int _{0}^{L}\left[\int _{-\infty }^{\unicode[STIX]{x1D702}}\left(\frac{|\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}|^{2}}{2}-\unicode[STIX]{x1D714}y\unicode[STIX]{x1D719}_{x}\right)\text{d}y\right]\text{d}x+\int _{0}^{L}\left(\frac{g}{2}\unicode[STIX]{x1D702}^{2}+\frac{\unicode[STIX]{x1D714}^{2}}{6}\unicode[STIX]{x1D702}^{3}+\unicode[STIX]{x1D6FC}\sqrt{1+\unicode[STIX]{x1D702}_{x}^{2}}\right)\text{d}x.\end{eqnarray}$$
All variations are assumed to vanish at the vertical boundary
 $T$
. First, we consider the variation of
 $H$
with respect to
 $\unicode[STIX]{x1D701}$
. The only term of interest is
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}H=\int _{0}^{L}\int _{-\infty }^{\unicode[STIX]{x1D702}}\unicode[STIX]{x1D735}\boldsymbol{\cdot }[\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D719}(\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}-\unicode[STIX]{x1D714}y\unicode[STIX]{x1D735}x)]\,\text{d}x\,\text{d}y=\int _{0}^{L}[\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D719}(\unicode[STIX]{x1D719}_{y}-\unicode[STIX]{x1D719}_{x}\unicode[STIX]{x1D702}_{x}+\unicode[STIX]{x1D714}\unicode[STIX]{x1D702}\unicode[STIX]{x1D702}_{x})]_{y=\unicode[STIX]{x1D702}}\,\text{d}x.\end{eqnarray}$$
Here, we used
 $\unicode[STIX]{x0394}\unicode[STIX]{x1D719}=0$
in
 $\unicode[STIX]{x1D6FA}$
, the vanishing of variations on
 $T$
, and the boundary condition
 $\unicode[STIX]{x1D719}_{y}=0$
at the bottom. Now observe that, at fixed
 $\unicode[STIX]{x1D702}$
,
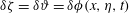 $\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}=\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}=\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D719}(x,\unicode[STIX]{x1D702},t)$
. Hence, recalling (5.6b
), at
 $y=\unicode[STIX]{x1D702}$
we obtain
 $$\begin{eqnarray}\unicode[STIX]{x1D702}_{t}=\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}}=\unicode[STIX]{x1D719}_{y}-\unicode[STIX]{x1D719}_{x}\unicode[STIX]{x1D702}_{x}+\unicode[STIX]{x1D714}\unicode[STIX]{x1D702}\unicode[STIX]{x1D702}_{x}.\end{eqnarray}$$
Next, we consider variations with respect to
 $\unicode[STIX]{x1D702}$
. At fixed
 $\unicode[STIX]{x1D701}$
, one has
 $$\begin{eqnarray}0=\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D701}=\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}-\frac{\unicode[STIX]{x1D714}}{2}\int _{0}^{x}\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}\,\text{d}s.\end{eqnarray}$$
Suppose that
 $\unicode[STIX]{x1D719}_{\ast }$
is the solution of the boundary value problem associated with the change
 $\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}$
. Then, from (5.22), we must have
 $$\begin{eqnarray}\unicode[STIX]{x1D719}_{\ast }(x,\unicode[STIX]{x1D702}+\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702},t)=\unicode[STIX]{x1D717}+\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D717}=\unicode[STIX]{x1D719}(x,\unicode[STIX]{x1D702},t)+\frac{\unicode[STIX]{x1D714}}{2}\int _{0}^{x}\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}\,\text{d}s.\end{eqnarray}$$
Hence, at first order in
 $\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}$
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D719}(x,\unicode[STIX]{x1D702},t)=\unicode[STIX]{x1D719}_{\ast }(x,\unicode[STIX]{x1D702},t)-\unicode[STIX]{x1D719}(x,\unicode[STIX]{x1D702},t)=\frac{\unicode[STIX]{x1D714}}{2}\int _{0}^{x}\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}\,\text{d}s-\unicode[STIX]{x1D719}_{y}\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}.\end{eqnarray}$$
On the other hand, by applying boundary conditions, the variation of the Hamiltonian corresponding to the change
 $\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}$
can be evaluated to be
 $$\begin{eqnarray}\unicode[STIX]{x1D6FF}H=\int _{0}^{L}\left\{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D719}\unicode[STIX]{x1D702}_{t}+\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}\left[\frac{|\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}|^{2}}{2}-\unicode[STIX]{x1D714}\unicode[STIX]{x1D702}\unicode[STIX]{x1D719}_{x}+g\unicode[STIX]{x1D702}+\frac{\unicode[STIX]{x1D714}^{2}}{2}\unicode[STIX]{x1D702}^{2}-\unicode[STIX]{x1D6FC}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}x}\left(\frac{\unicode[STIX]{x1D702}_{x}}{\sqrt{1+\unicode[STIX]{x1D702}_{x}^{2}}}\right)\right]\right\}_{y=\unicode[STIX]{x1D702}}\,\text{d}x.\end{eqnarray}$$
Hence, substituting (5.24) and (5.15) into (5.25) and integrating by parts, one obtains
 $$\begin{eqnarray}\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}=-\frac{\unicode[STIX]{x1D714}}{2}\left(\frac{\unicode[STIX]{x1D714}}{2}\unicode[STIX]{x1D702}^{2}-\unicode[STIX]{x1D712}\right)-\unicode[STIX]{x1D719}_{y}\unicode[STIX]{x1D702}_{t}+\frac{|\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}|^{2}}{2}-\unicode[STIX]{x1D714}\unicode[STIX]{x1D702}\unicode[STIX]{x1D719}_{x}+g\unicode[STIX]{x1D702}+\frac{\unicode[STIX]{x1D714}^{2}}{2}\unicode[STIX]{x1D702}^{2}-\unicode[STIX]{x1D6FC}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}x}\left(\frac{\unicode[STIX]{x1D702}_{x}}{\sqrt{1+\unicode[STIX]{x1D702}_{x}^{2}}}\right)\!.\quad\end{eqnarray}$$
Here, all quantities are evaluated at
 $y=\unicode[STIX]{x1D702}$
. Finally, at
 $y=\unicode[STIX]{x1D702}$
, we have
 $$\begin{eqnarray}\unicode[STIX]{x1D701}_{t}=\unicode[STIX]{x1D717}_{t}-\frac{\unicode[STIX]{x1D714}}{2}\int _{0}^{x}\unicode[STIX]{x1D702}_{t}\,\text{d}s=\unicode[STIX]{x1D719}_{t}+\unicode[STIX]{x1D719}_{y}\unicode[STIX]{x1D702}_{t}-\frac{\unicode[STIX]{x1D714}}{2}\left(\frac{\unicode[STIX]{x1D714}}{2}\unicode[STIX]{x1D702}^{2}-\unicode[STIX]{x1D712}\right)+\frac{\unicode[STIX]{x1D714}}{2}\left(\frac{\unicode[STIX]{x1D714}}{2}\unicode[STIX]{x1D702}^{2}(0,t)-\unicode[STIX]{x1D712}(0,t)\right).\end{eqnarray}$$
In the last passage we used (5.15). Recalling that
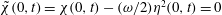 $\tilde{\unicode[STIX]{x1D712}}(0,t)=\unicode[STIX]{x1D712}(0,t)-(\unicode[STIX]{x1D714}/2)\unicode[STIX]{x1D702}^{2}(0,t)=0$
and substituting (5.6a
) with
 $f=0$
in (5.26), from (5.27) we arrive at
 $$\begin{eqnarray}\unicode[STIX]{x1D701}_{t}=-\frac{\unicode[STIX]{x1D6FF}H}{\unicode[STIX]{x1D6FF}\unicode[STIX]{x1D702}}=-\frac{|\unicode[STIX]{x1D735}\unicode[STIX]{x1D719}|^{2}}{2}-g\unicode[STIX]{x1D702}+\unicode[STIX]{x1D6FC}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}x}\left(\frac{\unicode[STIX]{x1D702}_{x}}{\sqrt{1+\unicode[STIX]{x1D702}_{x}^{2}}}\right)+\unicode[STIX]{x1D719}_{y}\unicode[STIX]{x1D702}_{t}+\unicode[STIX]{x1D714}\unicode[STIX]{x1D702}\unicode[STIX]{x1D719}_{x}-\frac{\unicode[STIX]{x1D714}}{2}\unicode[STIX]{x1D712}-\frac{\unicode[STIX]{x1D714}^{2}}{4}\unicode[STIX]{x1D702}^{2}.\end{eqnarray}$$
In light of (5.21) and (5.28), we have thus shown that the water wave system (5.6) can be cast in canonical Hamiltonian form in terms of the variables
 $(\unicode[STIX]{x1D701},\unicode[STIX]{x1D702})$
.
5.4 Translational symmetry
The remaining task is to show that travelling wave solutions of system (5.6) exhibit translational symmetry. A travelling wave solution is defined by the property that it can be written as a function of
 $x^{\prime }=x-ct$
, i.e.
 $$\begin{eqnarray}\unicode[STIX]{x1D701}=\unicode[STIX]{x1D701}(x^{\prime }),\quad \unicode[STIX]{x1D702}=\unicode[STIX]{x1D702}(x^{\prime }).\end{eqnarray}$$
That such solutions, if they exist, are symmetric under translation can be deduced by the invariance of the action
 ${\mathcal{S}}=\int _{0}^{t}{\mathcal{L}}\,\text{d}t^{\prime }$
, where
 ${\mathcal{L}}$
is the Lagrangian of the system, under the exchange
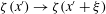 $\unicode[STIX]{x1D701}(x^{\prime })\rightarrow \unicode[STIX]{x1D701}(x^{\prime }+\unicode[STIX]{x1D709})$
and
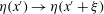 $\unicode[STIX]{x1D702}(x^{\prime })\rightarrow \unicode[STIX]{x1D702}(x^{\prime }+\unicode[STIX]{x1D709})$
for any choice of the displacement
 $\unicode[STIX]{x1D709}\in \mathbb{R}$
. Since
 $\unicode[STIX]{x1D701}$
acts as a canonical momentum, the Lagrangian
 ${\mathcal{L}}$
is related to the Hamiltonian
 $H$
according to
 $$\begin{eqnarray}{\mathcal{L}}=\int _{0}^{L}\unicode[STIX]{x1D701}\unicode[STIX]{x1D702}_{t}\,\text{d}x-H.\end{eqnarray}$$
The translational symmetry associated with travelling wave solutions implies the existence of a conservation law in accordance with Noether’s theorem. The conserved quantity is the total momentum in the
 $x$
-direction
 $$\begin{eqnarray}\unicode[STIX]{x1D648}_{x}=\int _{0}^{L}\left(\int _{-\infty }^{\unicode[STIX]{x1D702}}v_{x}\,\text{d}y\right)\text{d}x.\end{eqnarray}$$
It can be easily verified that, for travelling wave solutions,
 $\unicode[STIX]{x1D648}_{x}$
is constant.
In conclusion, since we have shown that system (5.6) can be cast in canonical Hamiltonian form, and that travelling wave solutions exhibit translational symmetry, the result proved in §§ 3 and 4 applies: exchange of stability will occur at those wave speeds where energy becomes stationary. Notice that this remains true for travelling waves without reflectional symmetry.
6 Concluding remarks
In this paper, the superharmonic instability of travelling wave solutions in canonical Hamiltonian systems was examined. By a linear stability analysis, it was shown that, if the travelling wave exhibits translational symmetry, exchange of stability occurs when energy is stationary with respect to wave speed.
This result generalizes the analysis of Saffman (Reference Saffman1985), who considered wave profiles with reflectional symmetry. Since the present calculations are independent of the specific physical system under consideration, they reflect a general property of Hamiltonian dynamics. The argument is thus expected to apply to water wave systems that possess a proper Hamiltonian structure, even in the presence of reflectionally asymmetric wave profiles. In particular, in light of the canonical Hamiltonian formulation of water waves with constant vorticity due to Wahlen (Reference Wahlen2007), Tanaka’s instability (Tanaka Reference Tanaka1983) should occur in water waves with constant vorticity, as discussed in § 5. This has been confirmed numerically by Murashige & Choi (Reference Murashige and Choi2019) for wave profiles endowed with reflectional symmetry.
We remark that our result applies to general (non-canonical) Hamiltonian systems (Morrison Reference Morrison1998) if a suitable change of variables can be found so that the transformed Poisson operator is in Darboux form (Littlejohn Reference Littlejohn1982), i.e. the system can be described by a set of canonically conjugated variables plus a given number of constants of motion (Casimir invariants). This is the case, for example, of the ideal Euler equations, which can be cast in Darboux form in terms of Clebsch parameters (Yoshida & Morrison Reference Yoshida and Morrison2017).
Acknowledgements
The research of N.S. was supported by JSPS KAKENHI grant no. 18J01729, and that of M.Y. by JSPS KAKENHI grant no. 17H02860.


