1. Introduction
Turbulence modelling remains a central challenge in modern physics, particularly for wall-bounded flows where strong inhomogeneity and anisotropy complicate universal scaling (Jiménez Reference Jiménez2018). While the Kolmogorov–Obukhov 1941 (K41) (Kolmogorov Reference Kolmogorov1941) theory provides robust descriptions for homogeneous, isotropic turbulence in the infinite Reynolds number limit, its applicability to the near-wall region, dominated by coherent structures, is limited. Developing a more general theoretical framework to these turbulent regimes is essential for modelling processes like particle resuspension, where the detachment mechanism for particles fully immersed within the viscous sublayer (with dimensionless diameters smaller than five wall units,
 $d_{\!p}^+ \lt 5$
) remains unresolved (Henry, Minier & Brambilla Reference Henry, Minier and Brambilla2023).
The physical mechanism linking near-wall coherent structures to particle resuspension has been a subject of ongoing debate. Although Cleaver & Yates (Reference Cleaver and Yates1973) initially proposed that turbulent bursts could directly lift particles, later observations showing that detachment is typically preceded by rolling (Henry et al. Reference Henry, Minier and Brambilla2023), complicating this view. Subsequent investigations have produced contrasting results: some experiments suggest that bursting has a negligible impact since the associated uplift angles are too small (Yung, Merry & Bott Reference Yung, Merry and Bott1989), whereas others, including direct numerical simulation (DNS) studies, explicitly link detachment to sweep and ejection events (Soltani & Ahmadi Reference Soltani and Ahmadi1995; van Hout Reference van Hout2013).
To capture this dynamics, two main approaches exist for modelling the driving forces of particle detachment. One attributes detachment to particle–surface interactions, such as collisions with asperities (Guingo & Minier Reference Guingo and Minier2008), while the other attributes detachment to particle–fluid interactions generated by the near-wall coherent structures (Soltani & Ahmadi Reference Soltani and Ahmadi1995). Nevertheless, theoretical models have struggled to resolve the physical mechanism linking these coherent structures to particle resuspension. As van Hout (Reference van Hout2013) noted, `Particularly within the field of particle resuspension, most of the theoretical works seems to neglect the incorporation of the actual physical mechanism linking coherent structures with resuspension’.
Addressing this issue requires accounting for the flow structure. The viscous sublayer (y+
 $\lt$
5, where
 $y^{+} = yu_{\tau }/\nu$
denotes the dimensionless wall-normal coordinate,
 $u_{\tau }$
is the friction velocity and
 $\nu$
is the kinematic viscosity) is not laminar but consists of alternating high- and low-velocity streaks exhibiting significant temporal persistence (Kline et al. Reference Kline, Reynolds, Schraub and Runstadler1967). Quadrant analysis (Wallace, Eckelmann & Brodkey Reference Wallace, Eckelmann and Brodkey1972), identifies these coherent motions as ejections (Q2) and sweeps (Q4), which dominate turbulence production and manifest as low- and high-drag events, respectively (Agrawal et al. Reference Agrawal, Ng, Davis, Park, Graham, Dennis and Poole2020). These intermittent motions also serve as fundamental mechanisms driving particle transfer and segregation within the turbulent boundary (Marchioli & Soldati Reference Marchioli and Soldati2002). Furthermore, recent high-resolution DNS and experimental studies (Roccon, Zonta & Soldati Reference Roccon, Zonta and Soldati2019; Guerrero, Lambert & Chin Reference Guerrero, Lambert and Chin2020) confirm that the viscous sublayer hosts rare, intense intermittent events (e.g. backflow) originating from multi-scale interactions. Importantly, the existence of identifiable precursor signatures for these events implies that near-wall fluctuations are not random, independent increments, but organised sequences with distinct temporal correlations.
We hypothesise that this structural intermittency governs the high-order fluctuations responsible for particle detachment. However, existing stochastic models (Guingo & Minier Reference Guingo and Minier2008; Fu et al. Reference Fu, Chao, So and Leung2013; Henry & Minier Reference Henry and Minier2014; Hu, Johnson & Meneveau Reference Hu, Johnson and Meneveau2023; Ben Shlomo et al. Reference Ben Shlomo, Almog, Klausner, Fattal and Berkovich2024) predominantly rely on the classical K41 theory, treating velocity fluctuations as a Markovian process. This implicitly assumes that velocity increments become uncorrelated over time (i.e. the flow has no ‘memory’). While this assumption is justified for some free shear flows (Renner, Peinke & Friedrich Reference Renner, Peinke and Friedrich2001), it is questionable in the viscous sublayer, where persistent coherent structures induce strong spatial and temporal correlations. Nevertheless, previous Markovian models often achieve good reconstruction of experimental data by fitting free parameters (associated with particle–surface or particle–flow interactions) to the measurements, potentially masking the underlying mechanism of the process.
In the present study, we investigate whether the Markovian assumption is physically justified in the near-wall region. We analyse DNS data to characterise the memory of the flow and introduce a generalised non-Markovian stochastic framework. Consistent with the refined Kolmogorov theory 1962 (K62) for intermittent turbulence (Kolmogorov Reference Kolmogorov1962), this model explicitly links the statistics of particle detachment to the persistent dynamics of coherent structures.
2. Theory and methodology
As introduced above, near-wall coherent structures manifest as high- and low-drag events in the turbulent boundary layer (Örlü & Schlatter Reference Örlü and Schlatter2011). Their persistent nature implies that the forces acting on a particle are not random but strongly time correlated. Accordingly, we focus on characterising the time scales, amplitudes and memory properties of these events to link particle motion within the viscous sublayer to the underlying flow topology. We analyse DNS data from the John Hopkins Turbulent Database for a fully developed turbulent channel flow at
 $\textit{Re}_{\tau } = u_{\tau }h/\nu \approx 1{\,}000$
(where h is the channel half-height) (Graham et al. Reference Graham2016). The simulation domain covers
 $8\pi h \times 2h \times 3\pi h$
in the streamwise, x, wall-normal, y, and spanwise, z directions, respectively, and fully resolves scales from energy-containing eddies down to the dissipative Kolmogorov scales. The extracted time series utilises the 4000 stored database snapshots, which have a non-dimensional database time step of
 $\delta t = 0.0065$
. This provides a fine temporal resolution of
 $\Delta t^+ = 0.325$
in viscous units. Given that the stochastic resuspension framework is formulated as a single-particle model, the particle concentration is assumed to be sufficiently dilute so that the particles do not interact with each other or significantly alter the flow. Under these conditions, the particles respond to the turbulent velocity field without feeding back onto it, consistent with the one-way coupling assumption. We model tungsten particles with
 $d_{\!p}=13 \rm \,{\unicode{x03BC}} m$
diameter, corresponding to a particle Reynolds number or dimensionless diameter of
 $\textit{Re}_{\!p}=d_{\!p}^+=d_{\!p}u_\tau /\nu = 0.013$
and a Stokes number of
 $\textit{St}^+=\rho _{p}(d_{\!p}^+)^2/18\rho _{\!f} = 0.18$
(where
 $\rho _{p}$
and
 $\rho _{\!f}$
are the particle’s and fluid’s density, respectively) in wall units. Given these small values of
 $d_{\!p}^+$
and
 $\textit{St}^+$
, the one-way coupling assumption remains valid because the system is in the dilute, single-particle limit, where momentum transfer to the bulk fluid is negligible. This is supported by the experimental findings of Quibeuf, Charru & Lacaze (Reference Quibeuf, Charru and Lacaze2020), who demonstrated that heavy, inertial particles (e.g. zirconium) with
 $\textit{Re}_{\!p}\lt 10$
follow fluid velocity fluctuations within the viscous sublayer without significantly altering the local flow structure. Furthermore, the baseline Markovian stochastic framework (Ben Shlomo et al. Reference Ben Shlomo, Almog, Klausner, Fattal and Berkovich2024) was originally validated against measurements of tungsten particles, confirming the robustness of the one-way coupled stochastic approach for dense particles in this regime. In our stochastic-Lagrangian framework, the simulation is initialised with the particles at rest (their initial velocity is zero) directly on the surface. Because their dimensionless diameter is significantly smaller than the sublayer height, the particles are deeply immersed within the viscous sublayer.
We identify events using an amplitude criterion based on the normalised wall shear stress (WSS), defined as the ratio of the instantaneous WSS value to its time-averaged value,
 $\tau _{w}/\left \langle \tau _{w} \right \rangle$
. An amplitude criterion is adopted, where events are classified as high or low drag when the normalised WSS exceeds a
 $\pm$
5 % threshold. This specific value provides a physical balance: it isolates distinct energetic structures from background noise while avoiding the aggressive filtering of larger amplitude thresholds (e.g.
 $\pm 10\,\%$
) or strict minimum-time criteria. This allows us to capture the full spectrum of short-time-scale sublayer events relevant to particle resuspension, while improving the statistical robustness (Pereira, Thompson & Mompean Reference Pereira, Thompson and Mompean2019). Notably, while varying these thresholds alters the absolute numerical value of the resulting event decay rates (
 $\lambda$
), the underlying qualitative exponential nature of the event distributions remains consistent. A recent research demonstrated that adopting inner scaling (
 $\mathrm{\Delta }t^{+} = \mathrm{\Delta }tu_{\tau }^{2}/\nu$
) renders the fraction of time spent in high- and low-drag events independent of the friction Reynolds number
 $\textit{Re}_{\tau }$
(Agrawal et al. Reference Agrawal, Ng, Davis, Park, Graham, Dennis and Poole2020). Based on this finding, we employed inner time scaling in our analysis. To quantify memory effects in the WSS signal, we estimate the Hurst exponent (H). The Hurst exponent characterises the long-range temporal dependence of a signal, where
 $H=0.5$
indicates an uncorrelated Markovian process and
 $0.5 \lt H \lt 1$
indicates persistent flow memory. We estimate
 $H$
using rescaled range (R/S) analysis (Hurst Reference Hurst1951). Because the DNS data represent a statistically stationary flow, R/S analysis provides a robust estimation while avoiding the artefactual curvature and detrending errors known to affect other methods, such as detrended fluctuation analysis, when applied to stationary or weak-nonlinear signals (Bryce & Sprague Reference Bryce and Sprague2012). The R/S analysis is described as follows. The sample length, n, defines a temporal window over which the near-wall turbulent fluctuations are evaluated. For each block of length n, the adjusted range R is computed as the difference between the maximum and minimum of the cumulative deviation from the block mean, capturing the largest persistent excursion of the shear stress relative to the local average. The standard deviation S represents the root-mean-square magnitude of the fluctuations within the same window, reflecting the local turbulent intensity. The ratio R/S thus provides a normalised measure of persistence relative to fluctuation strength, and its scaling with n yields the Hurst exponent H, which characterises the temporal correlation and memory in near-wall turbulence. Hence, H is obtained through a linear regression of the data according to the linear equation
 $\log (R/S) = \log (c) + H \log (n)$
, where c is a constant. Importantly, because this analysis evaluates the continuous signal, the extracted Hurst exponent is fundamentally independent of the amplitude threshold used for discrete drag event identification.
Our non-Markovian generalisation builds upon our previously introduced Lagrangian stochastic Markovian model, which demonstrated good agreement with experimental data (Ben Shlomo et al. Reference Ben Shlomo, Almog, Klausner, Fattal and Berkovich2024). The model (depicted in figure 1) assumes a particle that rolls in a single direction (Henry et al. Reference Henry, Minier and Brambilla2023), with its motion governed by a moment balance, M, about a pivot point
 \begin{equation} M \equiv I\frac {\mathrm{d}\omega }{\mathrm{dt}} = \textit{bF}_{\!D} + \frac {a}{2}F_{\!L} - r_{a}F_{a} - \frac {a}{2}\textit{mg}, \end{equation}
where I is the particle moment of inertia, approximated as a sphere and evaluated using the parallel axis theorem as
 $I = (7/20) m d_{\!p}^{2}$
. The particle diameter and mass are denoted by
 $d_{\!p}$
and m, respectively, g is the gravitational acceleration,
 $\omega$
is the particle angular velocity, a is the distance between consecutive surface asperities, ra
is the lever arm of the adhesion force and
 $b = \sqrt {(d_{\!p}/2)^{2} - (a/2)^{2}}$
. The hydrodynamic drag force is modelled using the Stokes formulation
 $F_D = 6\pi \rho _{\!f}\nu (d_{\!p}/2)\langle u \rangle f_x$
, where
 $\langle u \rangle$
is the fluid’s mean velocity in the streamwise direction at the particle’s position and
 $f_x=1.7$
is O’Neill’s wall-correction factor (Stokes Reference Stokes1851; O’Neill Reference O’Neill1968). The hydrodynamic lift force is modelled using the Mollinger & Nieuwstadt (Reference Mollinger and Nieuwstadt1996) formulation,
 $F_L = 5.3\pi \rho _{\!f}\nu ^2(d_{\!p}^+/2)^{1.87}f_y$
, where
 $d_{\!p}^+$
is the dimensionless particle diameter and
 $f_y=3.39$
is Maude’s wall-correction factor (Maude Reference Maude1963). The mean adhesion force is calculated using the Rabinovich approximation, which describes the interaction potential between a spherical particle and a rough surface
 $F_{a}=(A_{\!H}d_{\!p}/12z_0^2)[1/(1+29d_{\!p}R_q/a^2)+1/(1+1.82R_q/z_0)^2]$
, where
 $A_{\!H}$
is the Hamaker constant,
 $z_0$
is the distance of the closest approach between surfaces and
 $R_q$
is the root mean square roughness of the surface (Rabinovich et al. Reference Rabinovich, Adler, Ata, Singh and Moudgil2000). The parameters used to calculate the hydrodynamic forces are evaluated from the fluid’s or the particle’s physical properties, while the adhesion force parameters are evaluated from the surface characteristics which can be measured by atomic force microscopy (Peillon et al. Reference Peillon, Gélain, Payet, Gensdarmes, Grisolia and Pluchery2022).
Schematic diagram of the forces and physical parameters appearing in (2.1).

Within this framework, applying Reynolds decomposition separates the overall angular velocity
 $\omega$
into mean (
 $\langle \omega \rangle$
) and fluctuating (
 $\omega '$
) components. The mean component is determined by the forces in (2.1), while the fluctuating component is modelled as a stochastic process. Consistent with K41 theory (Kolmogorov Reference Kolmogorov1941), this model uses a standard Ornstein–Uhlenbeck process (OUP) (Risken Reference Risken1989)
 \begin{equation} \mathrm{d}\omega '(t) = -\omega '(t)\frac {\mathrm{d}t}{T} + \sqrt {\frac {2\sigma ^2}{T}} \, \mathrm{d}W(t), \end{equation}
where T is the integral time scale,
 $\sigma$
is a parameter that controls the variance and the autocorrelation of the process and
 $W (t )$
denotes a Wiener process (Risken Reference Risken1989). The random term
 ${\rm d}W(t)$
is expressed as
 $\sqrt {{\rm d}t}\xi$
, with
 $\xi$
being a non-correlated white noise sampled from a normalised Gaussian distribution independently at each time step. The resuspension criterion is fundamentally tied to the particle’s spatial correlation with the surface geometry. During a characteristic time interval
 $\Delta t$
, a rolling particle undergoes a displacement of
 $(\omega d_{\!p} / 2) \Delta t$
. If a particle rolls over the pivot, it will leave its original place and the original asperity can no longer affect the rolling action, so the rolling action will lose its correlation with the surface when the distance of the particle displaced is larger than
 $a$
, marking full detachment and resuspension. This kinematic condition yields the critical angular velocity threshold
 $\omega _c = 2a / (d_{\!p} \Delta t)$
. While the numerical simulation results naturally depend on
 $\Delta t$
, this parameter is not an arbitrary integration step. It strictly corresponds to the turbulent viscous time scale,
 $\Delta t = T_0 = \nu / u_\tau ^2$
. As demonstrated by Fu et al. (Reference Fu, Chao, So and Leung2013), evaluating the threshold over
 $T_0$
properly accounts for the physical turbulent energy-transfer time scale, rather than numerical artefact. It is important to highlight that, according to Fu et al. (Reference Fu, Chao, So and Leung2013), the parameter
 $\sigma$
depends on a model constant,
 $C_{0}$
, via the relationship
 $\sigma = \sqrt {2 C_0 T_0 \langle M{\prime }^2 \rangle } / I$
. Here,
 $\langle M'^2 \rangle$
is the variance of the fluctuating hydrodynamic moment, which can be computed from the local fluid Reynolds stresses (
 $\langle u^2 \rangle$
,
 $\langle v^2 \rangle$
,
 $\langle uv \rangle$
, where
 $u$
and
 $v$
are the fluid’s velocity components at the streamwise and wall-normal directions, respectively) evaluated at the particle’s position (the full analytical expansion is provided in the supplementary material, available at https://doi.org/10.1017/jfm.2026.11435). This leaves
 $C_0$
as the sole free parameter used to calibrate the magnitude of the stochastic forcing. While its precise physical interpretation is unclear, based on our hypothesis, we assume that the physical meaning of this constant reflects the intermittent dynamics in the viscous sublayer, induced by near-wall coherent structures.
The observed penetration of intermittent coherent structures into the viscous sublayer seems to contradict the assumption of uncorrelated white noise, as it may not adequately capture the inhomogeneous dynamics of near-wall turbulence. Faranda et al. (Reference Faranda, Pons, Dubrulle, Daviaud, Saint-Michel, Herbert and Cortet2014) demonstrated that Hurst exponents provide a useful measure of deviations from the K41-based Markovian description in inhomogeneous and anisotropic turbulent flows, linking these deviations to the presence of intermittent coherent structures. Motivated by this insight, we propose a generalised non-Markovian model in which the standard OUP is replaced with a fractional Ornstein–Uhlenbeck process (fOUP) (Cheridito, Kawaguchi & Maejima Reference Cheridito, Kawaguchi and Maejima2003). This formulation is consistent with the refined K62 theory (Kolmogorov Reference Kolmogorov1962) and is obtained by replacing the Wiener process increment
 $\mathrm{d}W(t)$
in (2.2) with an increment of fractional Brownian motion (fBm),
 $\mathrm{d}B^{H}(t)$
. The governing stochastic differential equation for the fluctuating component becomes
 \begin{equation} \mathrm{d}\omega '(t) = -\omega '(t)\frac {\mathrm{d}t}{T} + \sqrt {\frac {2\sigma ^2}{T}} \, \mathrm{d}B^{H}(t), \end{equation}
Here, the Hurst exponent H (estimated from DNS data in the results section) governs the memory of the process. For 0.5
 $\lt$
H
 $\lt$
1, the process becomes persistent, meaning that fluctuations tend to continue in the same direction over time, thus capturing the influence of coherent structures (Faranda et al. Reference Faranda, Pons, Dubrulle, Daviaud, Saint-Michel, Herbert and Cortet2014; Hung & Tsai Reference Hung and Tsai2024). The fBm can be represented as a cumulative integral of a Gaussian random process
 \begin{align} B^{H}(t) = \frac {1}{\varGamma \left ( H + \dfrac {1}{2} \right )} \int _{-\infty }^{0} \left [ (t-s)^{H-\frac {1}{2}} - (-s)^{H-\frac {1}{2}} \right ] \mathrm{d}W(s) + \frac {1}{\varGamma \left ( H + \dfrac {1}{2} \right )} \int _{0}^{t} (t-s)^{H-\frac {1}{2}} \mathrm{d}W(s), \end{align}
where
 $\varGamma ( H )$
is the gamma function (Mandelbrot & Van Ness Reference Mandelbrot and Van Ness1968). The derivation of the conditional probability density function (PDF),
 $P(\omega ', t \mid \omega '_0, t_0)$
(with
 $t \gt t_{0}$
), follows directly from the Gaussian nature of the underlying noise. Because the governing linear stochastic differential equations are driven by standard and fBm, the resulting fluctuating angular velocity
 $\omega '$
is strictly a Gaussian process. By taking the exact time derivative of the Gaussian PDF and rearranging the terms (Risken Reference Risken1989), one obtains a generalised Fokker–Planck equation. The Fokker–Planck equation is not restricted to Markov processes, as both the Gaussian Markov process and fBm satisfy the same 1-point Fokker–Planck partial differential equation (McCauley Reference McCauley2012)
 \begin{equation} \frac {\partial }{\partial t} P(\omega ', t \mid \omega '_0, t_0) = \left [ -\frac {\partial }{\partial \omega '} D_1(\omega ', t) + \frac {\partial ^2}{\partial {\omega '}^2} D_2(\omega ', t) \right ] P(\omega ', t \mid \omega '_0, t_0), \end{equation}
Here, the drift coefficient
 $D_1$
represents the deterministic relaxation of the system, taking the form
 $D_1(\omega ', t) = -\omega '/T$
. The effective dispersion coefficient
 $D_2$
is explicitly dictated by the time derivative of the process variance,
 $V(t) = \langle {\omega '}^2(t) \rangle$
, defined as
 $D_2(t) = (1/2) {\rm d}V(t)/{\rm d}t + V(t)/T$
. Given the noise amplitude of
 $\sqrt {2\sigma ^2/T}$
, the standard OUP evaluates to a constant dispersion coefficient
 $D_2 = \sigma ^2/T$
. In contrast, the fOUP is distinguished by a uniquely defined, time-dependent
 $D_2(t)$
(scaling as
 $t^{2H-1}$
) that encapsulates the anomalous dispersion and temporal memory of the sublayer. For additional details on the effect of the Hurst parameter on the particle dynamics and the numerical algorithm of the non-Markovian model, see the supplementary material.
3. Results and discussion
A DNS-based analysis was conducted to characterise the spatio-temporal properties of high- and low-drag events within the viscous sublayer. Figure 2 presents the normalised fluctuating WSS as a function of inner-scaled time. Data were sampled at the centre of the channel in the streamwise and spanwise directions, specifically
 $(4\pi , 1.5\pi )$
, at
 $0.5 \lt y^{+} \lt 1.5$
in the wall-normal direction, corresponding to the lower portion of the viscous sublayer. At each time where the normalised WSS exceeded the
 $\pm$
5 % threshold relative to the mean, a high- or low-drag event was identified and recorded for subsequent analysis. Figure 2 shows that the viscous sublayer exhibits substantial shear fluctuations, reaching deviations of up to 10 % from the mean, in agreement with previous observations (Tardu Reference Tardu2014). These excursions are not merely random noise, as they represent the imprint of persistent coherent structures that penetrate into the viscous sublayer (Guerrero et al. Reference Guerrero, Lambert and Chin2020). The identification of discrete high- and low-drag events (marked in red and blue) confirms that the particle experiences the flow as a sequence of distinct forcing intervals. Collectively, these results support the adoption of a time-correlated, non-Markovian modelling framework to capture the near-wall flow dynamics in the viscous sublayer.
Normalised fluctuating WSS at the centre of the channel in the streamwise and spanwise directions
 $(4\pi , 1.5\pi )$
, as a function of inner-scaled time. Data were sampled within the viscous sublayer
 $0.5 \lt y^{+} \lt 1.5$
. High-drag events (red) and low-drag events (blue) are highlighted whenever the threshold criterion is exceeded.

We next calculate the PDF of duration and occurrence frequency of high- and low-drag events by extending the analysis in figure 2 to 100 streamwise–spanwise locations within the viscous sublayer. Figure 3 presents the resulting PDFs of event durations, and its inset shows the histogram of the time intervals between consecutive events. Each distribution can be fitted with an exponential function of the form
 $P ( \mathrm{\Delta }t^{+} ) = \textit{Ae}^{- \lambda \mathrm{\Delta }t^{+}}$
, where
 $A$
is the amplitude and
 $\lambda$
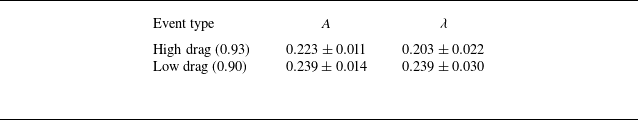
is the decay rate. We note that, since the time is expressed in inner-scaled, dimensionless units, the resulting decay rate is dimensionless. As illustrated in figure 3, both PDFs are well described by a single exponential with a reasonable goodness of fit. Nevertheless, while the single exponential fits successfully capture the bulk of the duration distributions, they mispredict the right tail. This deviation can be explained due to the multi-scale nature of wall-bounded turbulence. A single exponential curve assumes a single characteristic time scale, which adequately describes the dominant, high-frequency near-wall bursting cycle. However, the long high- and low-drag events populating the right tail are driven by longer time scales, likely resulting from the passage of highly elongated, meandering streamwise streaks or the temporal merging of multiple consecutive coherent structures. This behaviour is characteristic of a Poisson process, implying that the termination of a drag event is a random, memoryless occurrence. However, a crucial distinction should be made: while the switching between events follows Poissonian statistics (random occurrence), the dynamics during an event is governed by the coherent structure itself, and therefore exhibit strong temporal correlation. Table 1 summarises the exponential fit parameters. Notably, the decay rates obtained here (
 $\lambda \approx$
0.2) are approximately an order of magnitude larger than those reported by Agrawal et al. (Reference Agrawal, Ng, Davis, Park, Graham, Dennis and Poole2020). This difference likely stems from the differing event-selection threshold criteria. Agrawal et al. (Reference Agrawal, Ng, Davis, Park, Graham, Dennis and Poole2020) imposed a strict minimum-time-duration filter (
 $t^{+} \gt$
200), effectively isolating the larger structures, whereas our approach captures the full spectrum of viscous-sublayer events relevant to the short time scales of particle resuspension. The histogram of the time intervals between consecutive events (figure 3 inset), where high- and low-drag events are counted together, is based on 2354 detected events (counts). The median interval is 10.8
 $\mathrm{\Delta }t^{+}$
and the mean interval is 13.2
 $\mathrm{\Delta }t^{+}$
. These findings are consistent with previous numerical and experimental studies, which reported that the average spacing between near-wall velocity spikes is typically less than 20
 $\mathrm{\Delta }t^{+}$
(Liu, Klaas & Schröder Reference Liu, Klaas and Schröder2019).
Amplitude
 $(A)$
and decay rate
 $(\lambda )$
of high- and low-drag events within the viscous sublayer at
 $\textit{Re}_{\tau } \approx$
1000, including their standard error. The goodness of fit to the exponential function is indicated in brackets next to each event type.

The PDFs of high-drag (blue circles) and low-drag (orange squares) event durations, with corresponding exponential fits shown for high-drag events (blue dashed line) and low-drag events (orange dash–dotted line). The inset shows a histogram of the time interval between consecutive events. Both PDFs and histograms were obtained from analyses at 100 spatial locations in the streamwise–spanwise planes within
 $0.5 \lt y^{+} \lt 1.5$
.

To investigate the non-Markovian nature of the viscous-sublayer dynamics, we perform a time-correlation analysis to quantify the degree of temporal persistence and extract the Hurst exponent from the DNS data. This was accomplished using the R/S analysis (described in the theory section) that was applied to the temporal evolution of the wall-normal shear stress,
 $\tau _{w} ( t )$
, sampled within y+
 $\in$
(0.5, 1.5).
Figure 4 portrays the Hurst exponent estimation from DNS WSS time series using R/S analysis. Figure 4(a) presents a representative R/S calculation for a single spatial location (channel centre), while figure 4(b) displays a heat map of Hurst values computed at 100 spatial locations across the channel. The Hurst exponent varies between 0.79 and 0.87 with a median Hmed
= 0.84 and a mean
 $\overline {H}$
= 0.83. These values indicate pronounced long-range temporal correlations and strong persistence in the near-WSS signal, supporting a non-Markovian description of the turbulent fluctuations in the viscous sublayer. We note that the exact numerical value of the Hurst exponent may exhibit some Reynolds number dependence. Specifically, at higher Reynolds numbers, outer-layer large-scale motions increasingly amplitude modulate the near WSS, which could influence the value of
 $H$
(Mathis, Hutchins & Marusic Reference Mathis, Hutchins and Marusic2009). Nevertheless, due to the universal forming of coherent structures at turbulent boundary layers, we expect that our fundamental qualitative finding of persistent temporal correlations within the sublayer is a general feature of wall-bounded turbulence.
Estimation of the Hurst exponent using R/S analysis. (a) Example for a single point located at the channel centre in the streamwise and spanwise directions
 $(4\pi , 1.5\pi )$
and within
 $0.5 \lt y^{+} \lt 1.5$
. According to the R/S method, the slope of the linear fit yields a Hurst exponent of H = 0.84. (b) Heat map of Hurst exponent values computed from 100 spatial locations across the channel. The data point shown in (a) is indicated by a red square outline in (b).

Following the characterisation of the flow dynamics within the viscous sublayer and the integration of extracted time scales and correlation intensities into the non-Markovian resuspension model, we address a fundamental question: Given that the viscous sublayer is inherently non-Markovian (H
 $\approx$
0.84), why do classical Markovian resuspension models (Guingo & Minier Reference Guingo and Minier2008; Fu et al. Reference Fu, Chao, So and Leung2013; Ben Shlomo et al. Reference Ben Shlomo, Almog, Klausner, Fattal and Berkovich2024) often reproduce experimental data successfully? To resolve this, we investigate whether the free parameter in the Markovian model,
 $C_{0}$
, effectively compensates for the missing physics associated with flow memory. We perform comparative simulations using both the non-Markovian and Markovian frameworks, with parameters that characterise the tracking of tungsten particles (dp
= 13
 ${\unicode{x03BC}}$
m) on a hydrodynamically smooth surface (with root mean square roughness of 2.2 nm), ensuring full immersion in the viscous sublayer. All additional model parameters are specified in Ben Shlomo et al. (Reference Ben Shlomo, Almog, Klausner, Fattal and Berkovich2024). In the non-Markovian model, the event decay rate
 $\lambda$
was varied to probe the sensitivity of the system to intermittency, while in the Markovian model, the parameter
 $C_{0}$
which scales the stochastic forcing variance and is theoretically linked to the integral time scale of turbulent fluctuations, was systematically varied.
Resuspension fraction (RF) and absolute residual (AR) as a function of friction velocity for particles fully immersed within the viscous sublayer. (a) Comparison of the Markovian model (varying
 $C_{0}$
) with the non-Markovian model (at
 $\lambda =$
0.2). (b) Validation of the Markovian (at
 $C_{0} = 1 \times 10^{- 3}$
) and non-Markovian (at
 $\lambda =$
0.2) models with respect to experimental measurements of Peillon et al. (Reference Peillon, Gélain, Payet, Gensdarmes, Grisolia and Pluchery2022). (c) Non-Markovian model predictions for varying high- and low-drag event decay rates,
 $\lambda$
.

Figure 5(a) illustrates the sensitivity of the Markovian model to
 $C_{0}$
. As
 $C_{0} \rightarrow 0$
, the stochastic contribution vanishes, and resuspension is driven solely by mean forces, resulting in systematic underprediction. Crucially, we observe that, when
 $C_{0} = 1 \times 10^{- 3}$
, the specific value empirically calibrated by Fu et al. (Reference Fu, Chao, So and Leung2013) to match experimental measurements, the Markovian prediction aligns with our non-Markovian model (with
 $\lambda = 0.2$
and strictly without empirical scaling,
 $C_{0} = 1$
). This agreement reveals an important physical insight: under viscous-sublayer conditions, the non-Markovian and Markovian formulations can produce equivalent macroscopic predictions, but through fundamentally different mechanisms. The non-Markovian model achieves this predictively, avoiding artificial variance scaling, by explicitly incorporating the structure and memory of drag events through the H and
 $\lambda$
parameters, whereas the Markovian model achieves similar outcomes by tuning the empirical parameter
 $C_{0}$
. We therefore propose that
 $C_{0}$
acts not merely as a fitting parameter, but as a phenomenological surrogate for the integrated memory of high- and low-drag events. In effect, by tuning
 $C_{0}$
, previous studies effectively adjusted the intensity of the white-noise forcing to emulate the persistence imparted by coherent structures. Figure 5(b) displays the validation of the Markovian and non-Markovian models with respect to experimental measurements, utilising the absolute residual (defined as the difference between the predicted and measured resuspension fraction values). Because the baseline Markovian framework was previously validated against tungsten resuspension data (Peillon et al. Reference Peillon, Gélain, Payet, Gensdarmes, Grisolia and Pluchery2022; Ben Shlomo et al. Reference Ben Shlomo, Almog, Klausner, Fattal and Berkovich2024), and since the present non-Markovian model converges to its macroscopic predictions, the framework inherits its empirical validity.
To delineate the limits of this equivalence, figure 5(c) examines the effect of the event decay rate,
 $\lambda$
, on resuspension. We identify a distinct regime transition around a critical threshold of
 $\lambda \approx$
0.2. Rather than being a universal intrinsic flow constant, this numerical boundary represents the physical crossover point for the coupled particle–flow system under our specific drag event identification criteria and boundary conditions. It demarcates where the mean duration of the flow events (
 $1/\lambda$
) becomes comparable to the dynamic response time of the particle. In the strong intermittency regime (
 $\lambda$
 $\lt$
0.2), where events are long lived, the resuspension profile exhibits a pronounced plateau at low friction velocities (
 $u_{\tau }$
 $\lt$
1 m s−1). This regime is strongly non-Markovian, as the flow memory persists long enough for the particle to experience sustained forcing, leading to a dynamics that cannot be reproduced by the white-noise approximation used in figure 5(a). Importantly, the Markovian model fails to capture the characteristic plateau observed in this regime, regardless of the calibration of
 $C_{0}$
. Conversely, in the weak intermittency regime (
 $\lambda \gt$
0.2), events become shorter and more frequent, causing the plateau to disappear and the curve to smooth out. In this limit, coherent structures decay so rapidly that they appear as effectively uncorrelated fluctuations from the particle’s perspective, rendering the Markovian approximation physically justified. This aligns with observations in inhomogeneous canopy flows, where rapid velocity decorrelation time scale justifies a Markovian description (Shnapp et al. Reference Shnapp, Bohbot-Raviv, Liberzon and Fattal2020, Reference Shnapp, Liberzon, Bohbot-Raviv and Fattal2024). We emphasise that the validity of the Markovian approximation depends on the specific imposed boundary conditions. In the present analysis we assumed a hydrodynamically smooth wall, however, surface roughness is expected to reduce the sublayer thickness (Grass Reference Grass1971), potentially altering the frequency and dynamics of coherent structures. Furthermore, the assumption of a one-way coupling regime neglects particle–flow feedback mechanisms where, at higher concentrations, particles intensify sweep and ejection events (Luo et al. Reference Luo, Zhang, Luo, Wu and Fan2019), creating a coupled system likely requiring non-Markovian descriptions. Finally, for processes occurring higher in the boundary layer, such as particle deposition and sedimentation, the influence of large-scale structures becomes more pronounced, consistent with our calculation of a decay rate (
 $\lambda \approx$
0.1) at the buffer layer (y+
= 50). Recent work by Hung & Tsai (Reference Hung and Tsai2024) demonstrated that a non-Markovian model outperforms a Markovian formulation for reconstructing sedimentation measurements, utilising a decay rate (
 $\lambda \approx$
0.02) consistent with the stronger intermittency of the buffer layer. Thus, while the Markovian approximation can be tuned to describe simple sublayer resuspension, a non-Markovian framework offers a more general and physically grounded description that is essential for flows dominated by memory effects.
4. Concluding remarks
This study evaluates the Markovian assumption in modelling near-wall turbulence, using micron-sized particle detachment as a test case. While classical frameworks typically model turbulent velocity increments as memoryless (Markovian) processes consistent with Kolmogorov’s K41 hypothesis, we hypothesise that the presence of coherent structures necessitates a non-Markovian description that explicitly accounts for flow memory and intermittency, consistent with the refined K62 theory. Through a coupled theoretical–numerical framework parameterised from DNS data analysis, we demonstrate that the near-wall dynamics exhibits strong temporal persistence (
 $H \approx 0.84$
), requiring a non-Markovian description to accurately capture flow memory. Crucially, we reveal that the empirical success of classical Markovian models stems not from capturing instantaneous flow topology, but from tuning a free parameter,
 $C_0$
, to implicitly act as a phenomenological surrogate for flow memory. When
 $C_0$
is tuned to match the integrated energy of the persistent structures explicitly resolved by our non-Markovian formulation, the macroscopic predictions of both frameworks converge. Furthermore, we establish a physical limit of the Markovian approximation based on the event decay rate,
 $\lambda$
. Under strong intermittency (
 $\lambda \lt 0.2$
), extended temporal coherence makes a non-Markovian framework imperative. Conversely, rapid structural decay under weak intermittency (
 $\lambda \gt 0.2$
) justifies the Markovian assumption. We therefore conclude that the validity of the Markovian approximation is governed by the ratio of the structural decay time to the particle response time.
Supplementary material
Supplementary material is available at https://doi.org/10.1017/jfm.2026.11435.
Acknowledgements
The authors wish to thank Ziv Klausner, Yehuda Arav and Ilan Shemesh for fruitful discussions..
Funding
This work was supported by the Pazy Foundation (Grant ID: 133-2020) and the John R. Goldsmith Memorial Prize Fund.
Declaration of interests
The authors report no conflicts of interest.
Data availability statement
The data that support the findings of this study are available from the corresponding authors upon reasonable request.