1. INTRODUCTION
More than 40 years ago Stiny and Gips (Reference Stiny and Gips1972) introduced shape grammars as a generative approach to shape design. Stiny (Reference Stiny1980a) further detailed this concept and subsequently distinguished set grammars as a simple variant of shape grammars (Stiny, Reference Stiny1982). Since then, a significant amount of research has been published on shape and set grammars, both of which can be classified under the more general term “spatial grammars” (Krishnamurti & Stouffs, Reference Krishnamurti and Stouffs1993). Originally presented for paintings and sculptures, this concept has also been successfully applied in other domains, such as architecture, industrial design, decorative arts, and engineering. Several authors, for example, Chau et al. (Reference Chau, Chen, McKay, de Pennington and Gero2004) and Cagan (Reference Cagan, Antonsson and Cagan2001), provide overviews of existing spatial grammars.
The formalism for spatial grammars consists of four different components, including shapes, an initial shape, rules, and labels. Labels have been used for many different purposes in the definition of grammar rules, for example, to restrict the application of rules or to control the termination of the shape generation process. The goal of the research presented in this paper is to develop an integrated concept for labels that covers the typical uses of labels and can be incorporated into a visual, interactive three-dimensional (3-D) spatial grammar approach (Hoisl & Shea, Reference Hoisl and Shea2011). A central challenge in the development of grammar interpreters is the problem of matching the left-hand side (LHS) of a grammar rule for complex shapes. Labels can be used to simplify this problem and enable the consideration of more complex shapes in rule definition and application.
The paper starts with a background section that introduces the underlying grammar formalism, explains the theoretical aspects of labels, and analyzes the different uses of labels in existing grammar approaches. Next, an overview of the existing 3-D spatial grammar approach is given followed by the introduction of a new concept for 3-D labels. The general uses for labels covered by this concept are then described, followed by a detailed explanation of how they can be used for the simplification of LHS matching. A software prototype is presented to illustrate the approach through an example in mechanical engineering design. The paper ends with a discussion of the benefits and limitations of the presented approach as well as suggestions for future work.
2. BACKGROUND
2.1. Terminology and spatial grammar formalism
“Spatial grammars” is a general term that includes all kinds of grammars that define languages of shape (e.g., string grammars, set grammars, graph grammars, and shape grammars; Krishnamurti & Stouffs, Reference Krishnamurti and Stouffs1993). This paper focuses on set and shape grammars because the presented approach is based on a set grammar formulation, and among the related existing grammars, there are also several examples of shape grammars. With regard to labels, the main topic of this paper, there is no difference between set and shape grammars. The underlying formalisms of set and shape grammars are similar. Both are generative systems that generate shapes applying defined rules iteratively starting from an initial set or shape that exists within a defined vocabulary of shapes. A set grammar consists of four components and is formally defined as G = (S, L, R, I), where
• S is a finite set of shapes,
• L is a finite set of labels,
• R is a finite set of rules, and
• I is the initial set, where I is a subset of (S, L)0.
The set of labeled shapes, including the empty labeled shape, is (S, L)0 and is also called the vocabulary. The rewriting rules are defined in the form A → B, where A and B are both subsets of the vocabulary. To apply a rule to a given set of labeled shapes, called the working shape C, first, A in the LHS of a rule has to be detected in C. This matching process can make use of valid Euclidean transformations, t, that are applied to A, to find more possible matches of A in the working shape C. The transformed subset A is then subtracted from C and the transformed subset B of the right-hand side (RHS) of the rule is added, thus resulting in a new set of labeled shapes C′ where C′ = C – t(A) + t(B).
The formalism of shape grammars is basically the same, where I is the initial shape, A and B are shapes in the vocabulary, and rules apply to subshapes of labeled shapes to produce other labeled shapes. In comparison, set grammar rules apply to subsets of sets of labeled shapes to produce other such sets (Stiny, Reference Stiny1982). Therefore, designs generated by a set grammar consist of shapes in S. Designs defined by shape grammars, instead, consist of shapes and subshapes of shapes in S because the compositional units in designs can be decomposed and recombined in different ways (Stiny, Reference Stiny1982). Shape grammars work directly on spatial forms (Krishnamurti & Stouffs, Reference Krishnamurti and Stouffs1993), while set grammars treat designs as symbolic objects with geometric properties, which makes them more amenable to computer implementation (Stiny, Reference Stiny1982). However, because designs are made up of only symbolic objects in set grammars, in contrast to shape grammars, emergent shapes cannot be recognized nor transformed. The more general term spatial grammar is used throughout this paper.
2.2. Labels and their uses in spatial grammars
This section investigates the theoretical aspects of labels, presents a concise overview of common uses of labels, and describes how they are used in existing spatial grammars.
2.2.1. Theoretical aspects
Labels have been applied in various manners in the development of spatial grammars. Describing labels on a general level, they are used to restrict the ways that rules apply (Knight, Reference Knight1994), to introduce additional information (Stiny, Reference Stiny1992), to associate nongeometric data (Heisserman, Reference Heisserman1994), or to classify and distinguish basic elements, like points, lines, planes, or solids in shapes in different ways (Knight, Reference Knight2003).
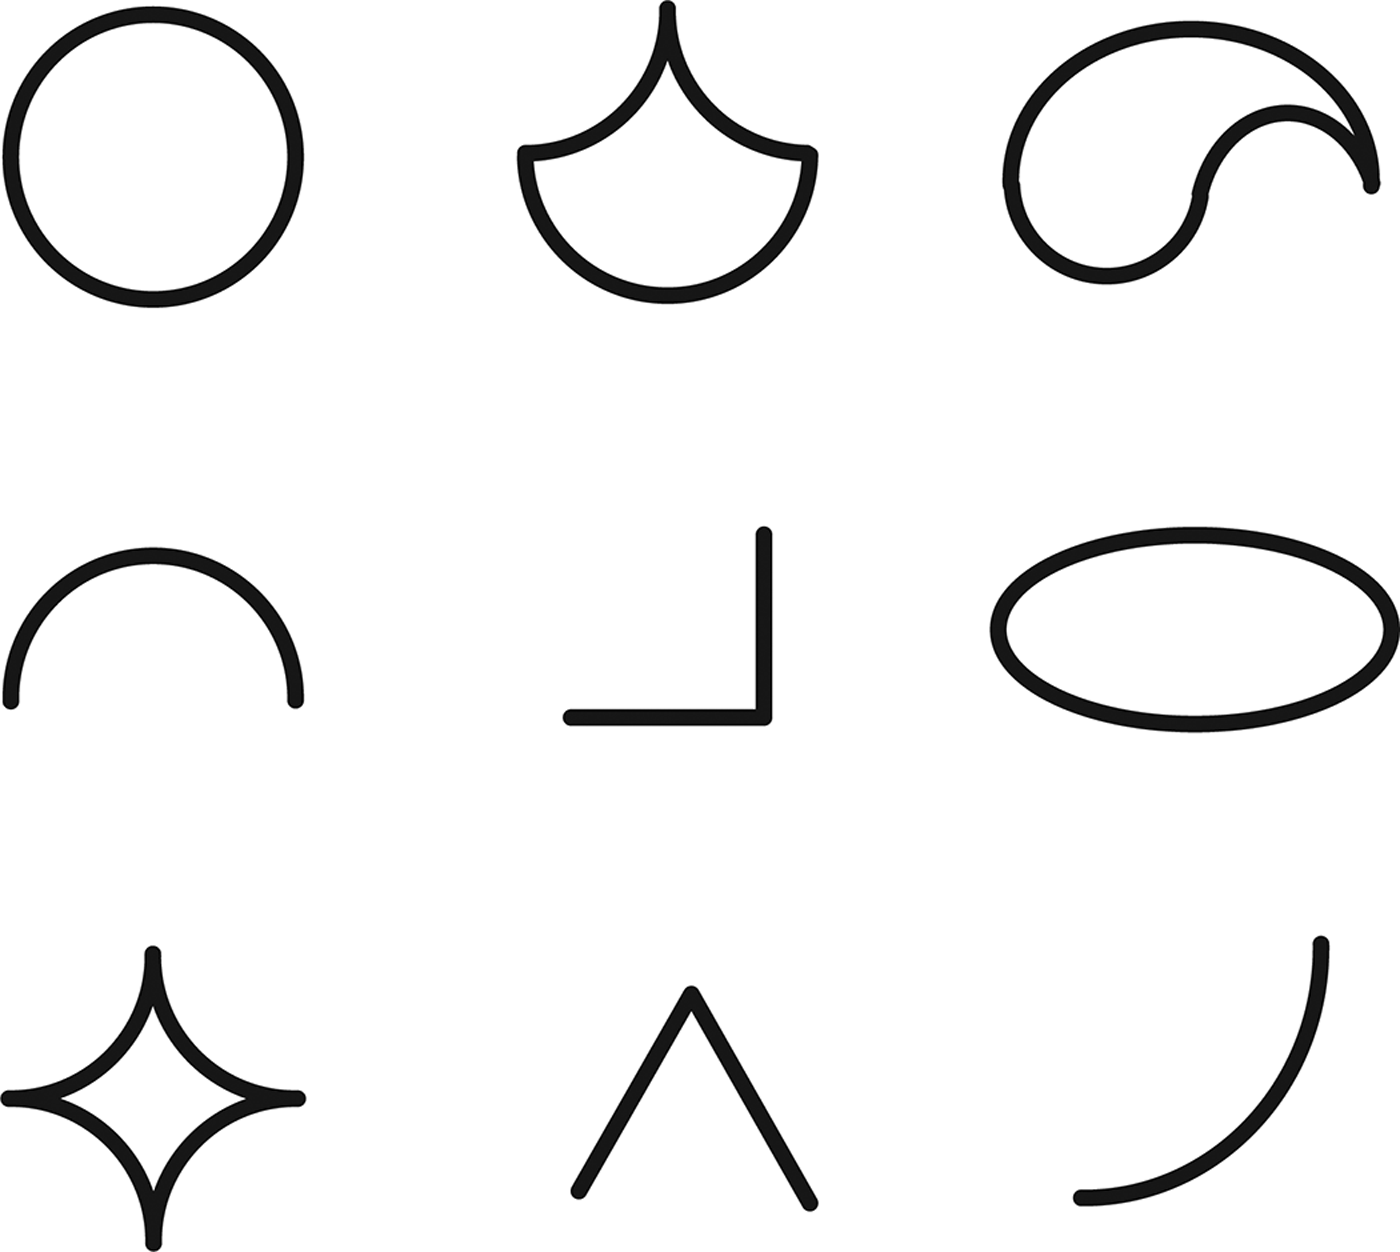
In the first formulation of the shape grammar formalism (Stiny & Gips, Reference Stiny and Gips1972), the second component of the formalism (cf. Section 2.1) is not explicitly defined as “labels,” but as a second finite set of shapes, called “markers.” In comparison to the first finite set of shapes (cf. S in Section 2.1), which contains terminal shape elements (“terminals”), markers are nonterminal shape elements. The precondition to use the two sets together in the definition of grammar rules is that they are disjoint so that they can be distinguished uniquely. Theoretically, any shape can be used as a marker, as long as it is not a subshape of a shape in the set of terminals or a terminal is not a subshape of a marker. Markers are treated like any other shape during the application of grammar rules, and therefore they can also be altered under Euclidean transformations, for example, scaled, translated, or rotated. Figure 1 shows some examples for markers used by Gips (Reference Gips1975) and Stiny (Reference Stiny1975).
Different examples for markers (according to Gips, Reference Gips1975; Stiny, Reference Stiny1975).

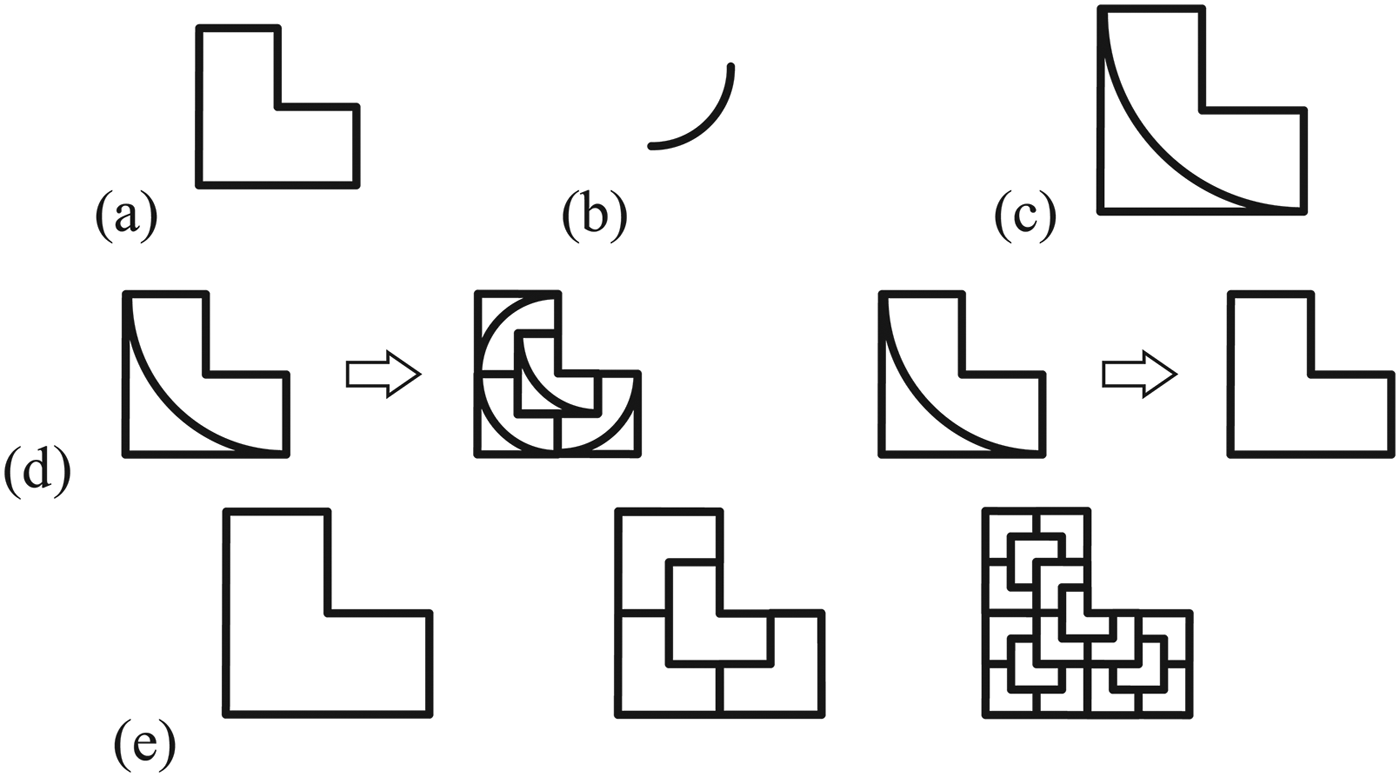
The definition of a rule contains at least one terminal and one marker in the LHS. Two examples can be seen in Figure 2d. They are composed using the shape in the set of terminals Figure 2a and the shape in the set of markers Figure 2b. The set of markers can also contain more than one shape, and differently shaped markers can be used in one side of a rule. The first role of markers described in the early shape grammar work (Stiny & Gips, Reference Stiny and Gips1972; Gips, Reference Gips1975; Stiny, Reference Stiny1975, Reference Stiny1976) is to restrict rule application to a specific part of the current working shape (CWS; called C′ in the formalism in Section 2.1). In this context, they can also be defined in a way that rules are applicable only once to any added shape. If there is no marker in the LHS of a rule, the rule might be applicable over and over to a shape. For example, without the marker, the first rule shown in Figure 2d could be applied more than once to the outer L-shaped geometry starting with the initial shape (Fig. 2c).
An example of a shape grammar using markers (according to Stiny, Reference Stiny1975).
The second role of markers is to represent nonterminal shape elements and control the termination of the shape generation process. For this purpose, in each grammar a rule is defined that results in the removal, or erasing, of existing markers in the CWS. For example, the second rule shown in Figure 2d serves this purpose. With no markers left in the CWS, no further rules in the grammar are applicable, and the generation process stops. Depending on when this rule is applied, different solutions are generated in the design language, for example, the three different designs illustrated in Figure 2e.
The third role of markers is to help determine the transformations required to apply rules. This comprises not only the location but also the relationship in orientation and scale between the rule applied and the shape to which it is applied. In this context, a marker can also remove symmetries (rotational and reflective) of a shape. Asymmetric markers, for example, the top right marker shown in Figure 1, can be used to force the rule application to a certain orientation. Further, the use of a marker can prevent infinite matches, for example, matching a shorter line in a longer line under translations or, in the case of shape grammars, matching rotationally symmetrical geometric objects under rotations.
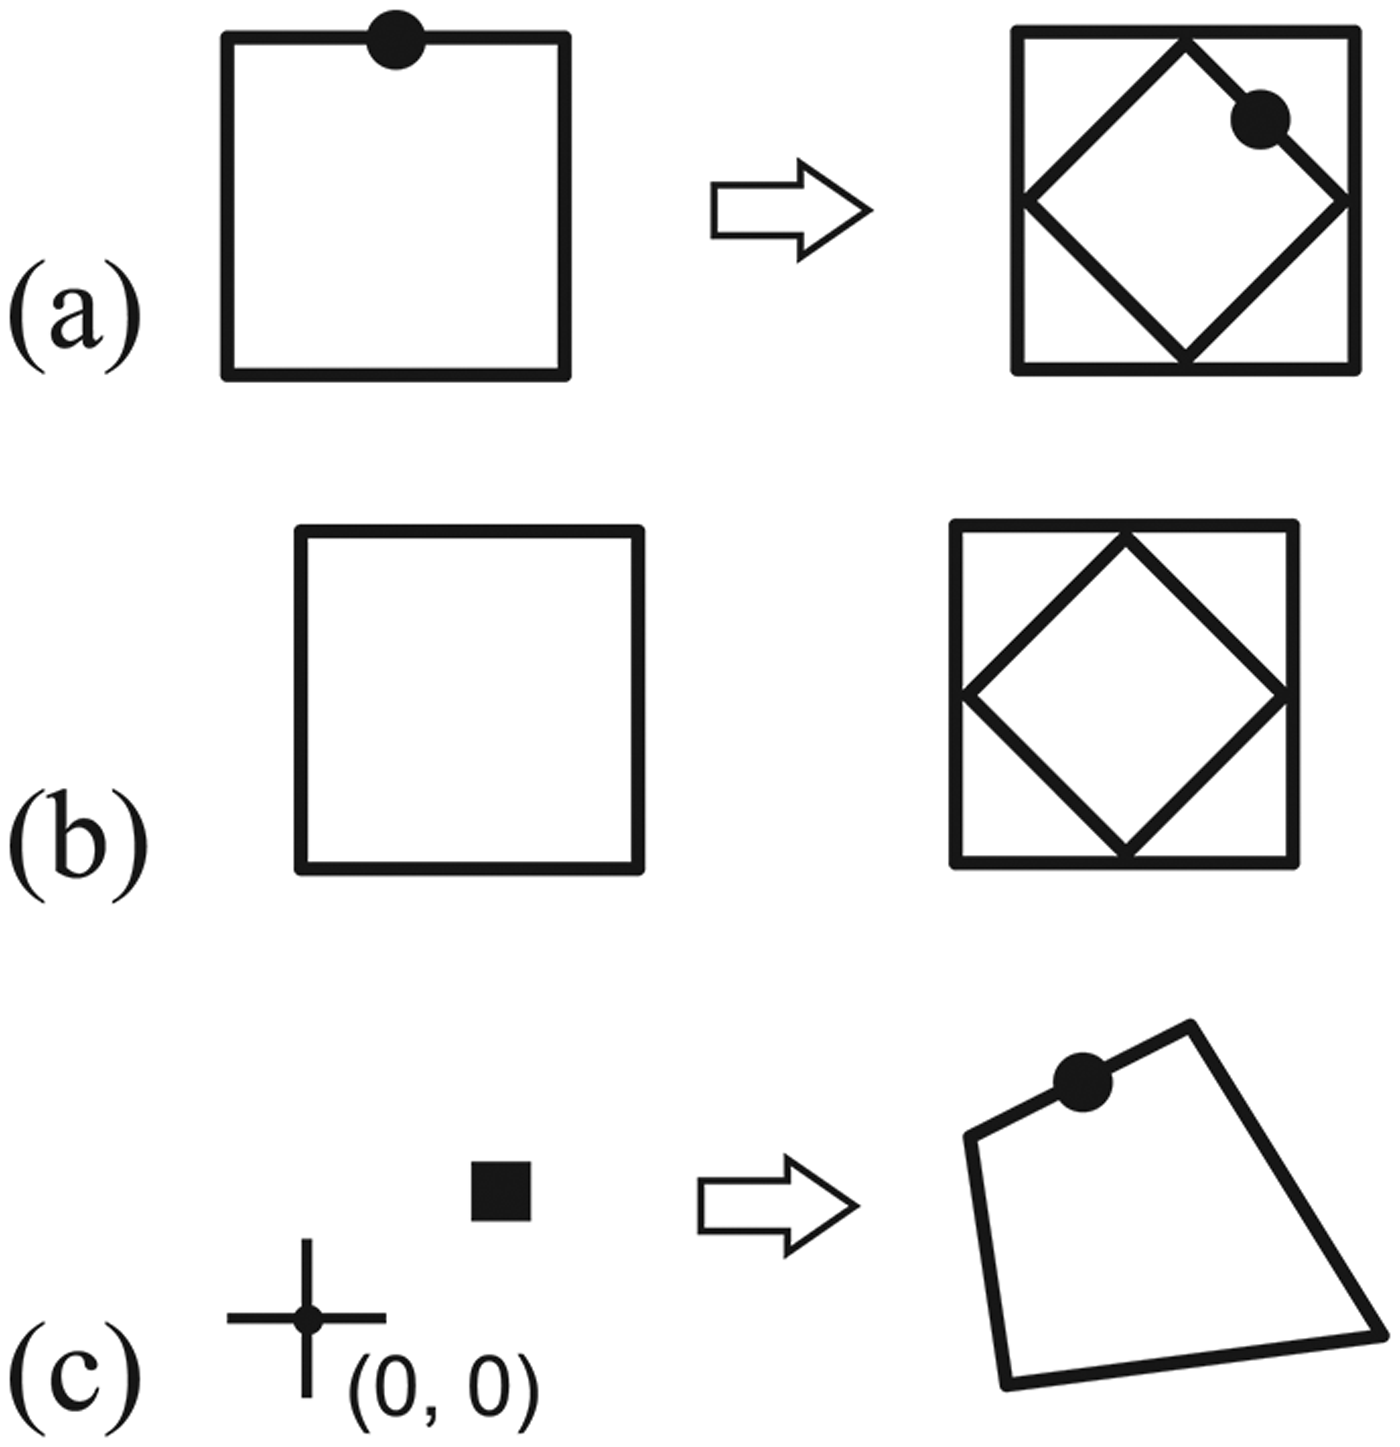
The further specification of the shape grammar formalism (Stiny, Reference Stiny1977, Reference Stiny1980a) uses an adapted formulation as the one presented for set grammars in Section 2.1. Here, the second component of the formalism is defined as a finite set of symbols. Association of a symbol to a point results in a labeled point, commonly referred to as “label.” In comparison to a marker, a label, or the symbol associated with a point, is invariant under Euclidean transformations. As a result, there are differences regarding the determination of the transformations required to apply rules (cf. third purpose described above). In general, however, the function of a label is also to help guide the shape generation process. Labeled points are used the same way as markers to define rules. A rule contains a labeled shape on both the LHS and the RHS (e.g., Fig. 3a). The labeled shape consists of a shape and a set of labeled points. If this set is empty, no symbols are associated with the shape (Stiny, Reference Stiny1980b), resulting in an unlabeled shape (e.g., Fig. 3b). The other way around, labels may also be associated with the empty shape, resulting in a “blank space” with only labels in it (e.g., Fig. 3c).
Different uses of labeled shapes in shape grammar rules (based on Stiny, Reference Stiny1980a).
It is further possible to define labeled parameterized points whose coordinates are not static values but variable. This concept is especially important for the definition of parametric shape grammars. Here the rules are based on parameterized shapes, and some or all of the parameter values are not predefined in the rule. Thus, a rule schema is defined that describes many different but related rules in one generalized rule (cf. Stiny, Reference Stiny1980a).
On the basis of these definitions and uses of labels, to date, labels have been applied in a wide range of scopes and have been represented in many different forms. The most common way to represent a label is a dot, or a small circle, that might be filled or empty. Other geometrical entities like squares and cylinders for 3-D rules have been used as well. In addition to geometrical shapes as symbols for labels, characters, or letters, and numbers have been used, often in combination with a geometrical symbol.
Knight (Reference Knight1983, Reference Knight1994) defines two categories of labels: spatial labels and state labels. Spatial labels are used to control where (i.e., the relative position in relation to a distinct subshape) and how (i.e., under what specific Euclidean transformations) rules apply to a CWS. Spatial labels have a specific location, but unlike shapes or the original idea of markers, their orientation or size has no influence and is invariant if a rule is applied under rotation or scale transformations. Often spatial labels are used to prevent application of rules to the same shape more than once or to make rules applicable only to the most recently added shape in a CWS. Another, very specific use is to define spatial labels in rules such that the shapes cannot interpenetrate each other once inserted in the CWS (Stiny, Reference Stiny1980b).
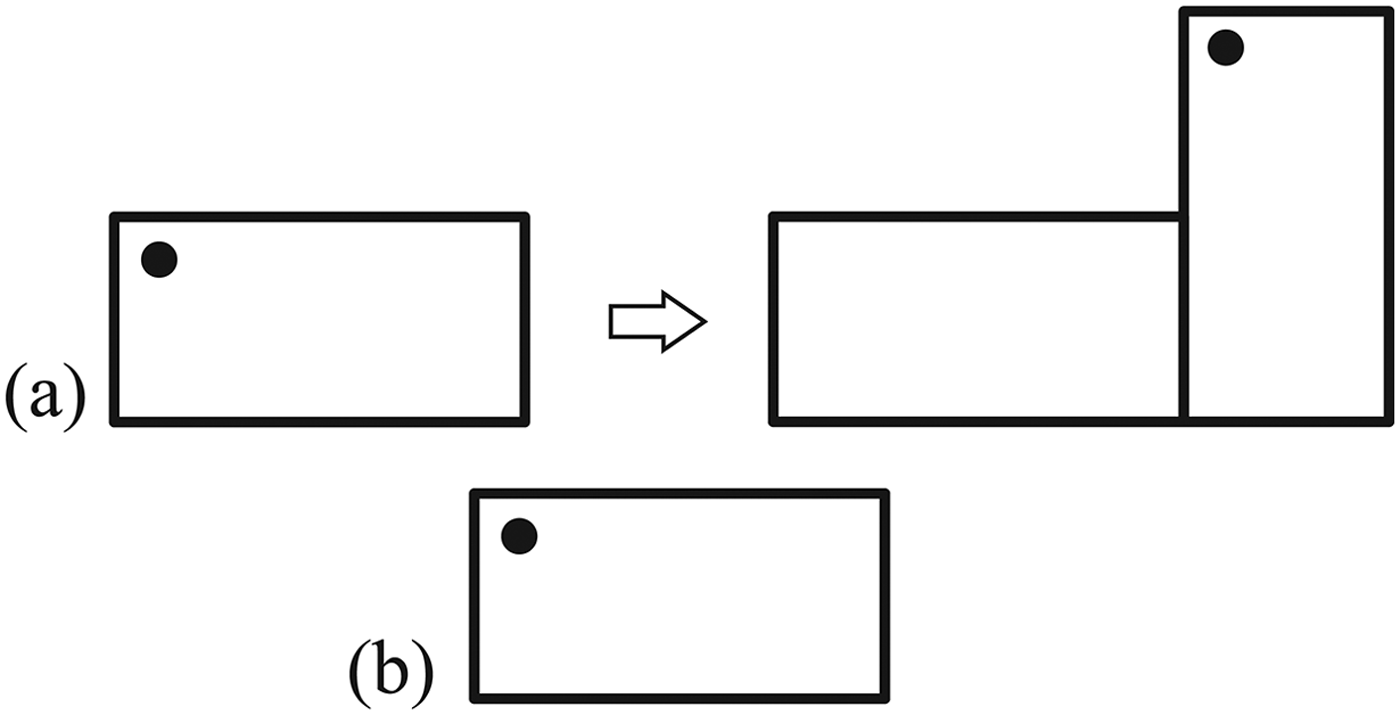
Figure 4a shows an example for a rule using spatial labels that combine the described purposes. Applying the rule to the initial set in Figure 4b, the label depicts the one transformation under which the rule is to be applied. Without using a label, there would be several different rotation or reflection transformations to match the rectangle. Applying the rule a second time, the label forces the LHS to match under a combined reflection and rotation transformation. Further, the LHS can only be matched to the rectangle with the label (i.e., the most recently added shape), and therefore the rule can only be applied once to any shape that is added to the CWS.
A rule using (a) spatial labels and (b) an initial set.
State labels are the second category defined by Knight (Reference Knight1994). They are used to define when rules apply or, more precisely, the sequence and the repetition (i.e., implicitly), the number of times a rule could be applied. This can also include the termination of the generation process, for example, if there are no further labels in a CWS, therefore no further rule is applicable. State labels are completely nonspatial (i.e., in comparison to spatial labels, not even the location matters). Often they are represented using numbers.
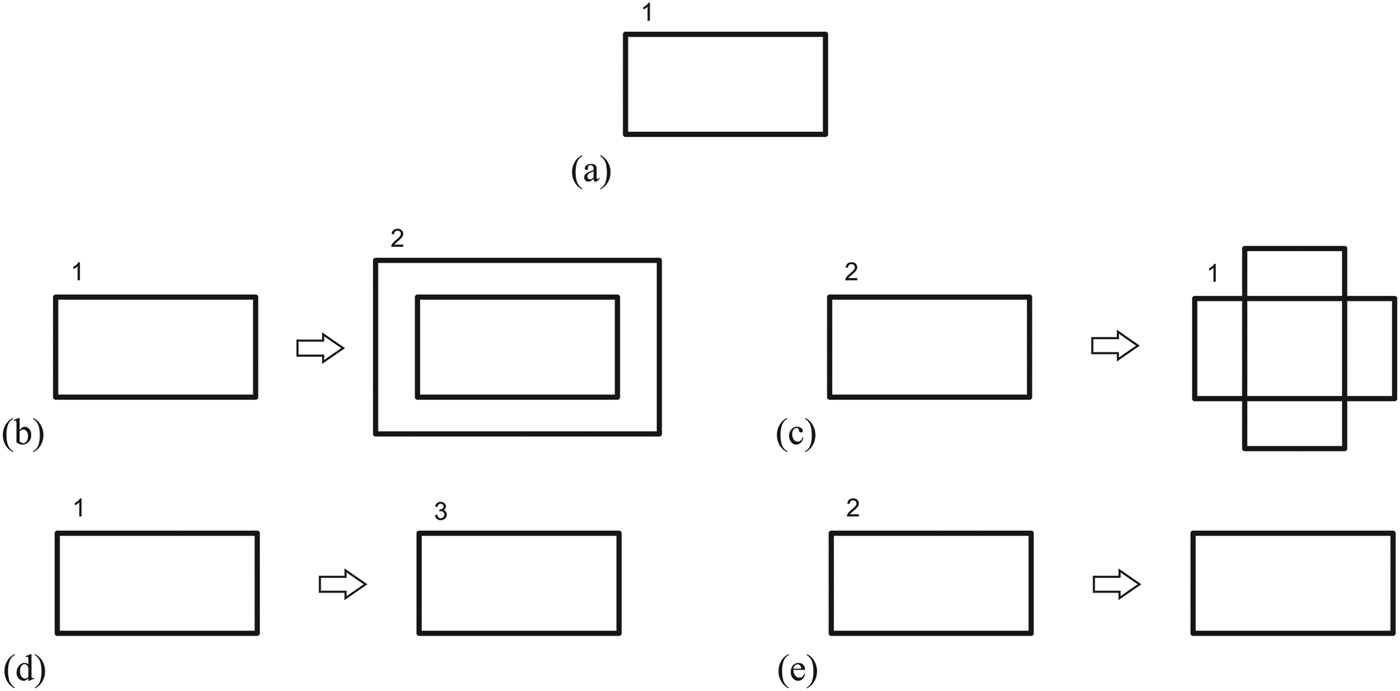
Figure 5 illustrates several rules using state labels. If only Rule (b) is defined in a grammar, it can be applied once to the initial set (a), whereas the state changes from “1” to “2.” This prevents further application of the rule, restricting the number of possible iterations. Adding a second Rule (c) to the grammar with a state label “2” in its LHS, the application is no longer restricted to a single iteration. Because the application of the rule changes the state back to “1,” the rule sequence is determined to apply Rules (b) and (c) repeatedly one after the other. To terminate the generation process, Rule (d) can be applied that changes state “1” into state “3.” This state is not part of any of the other rules, and thus, no further rule can be applied. Similarly, Rule (e) can be applied. This rule does not change the state but instead completely removes the label.
The (a) initial shape and (b–e) rules using state labels.
More than one label and also different kinds of labels (spatial and state) can be defined on either side of a rule. The only precondition is that the set of spatial and the set of state labels used in a grammar are disjoint. The different uses of labels described so far are summarized in the left branch, “constraints,” of Figure 6. Generally speaking, these uses of labels all introduce constraints restricting the application of rules.
(Color online) Concise overview of the use of labels.
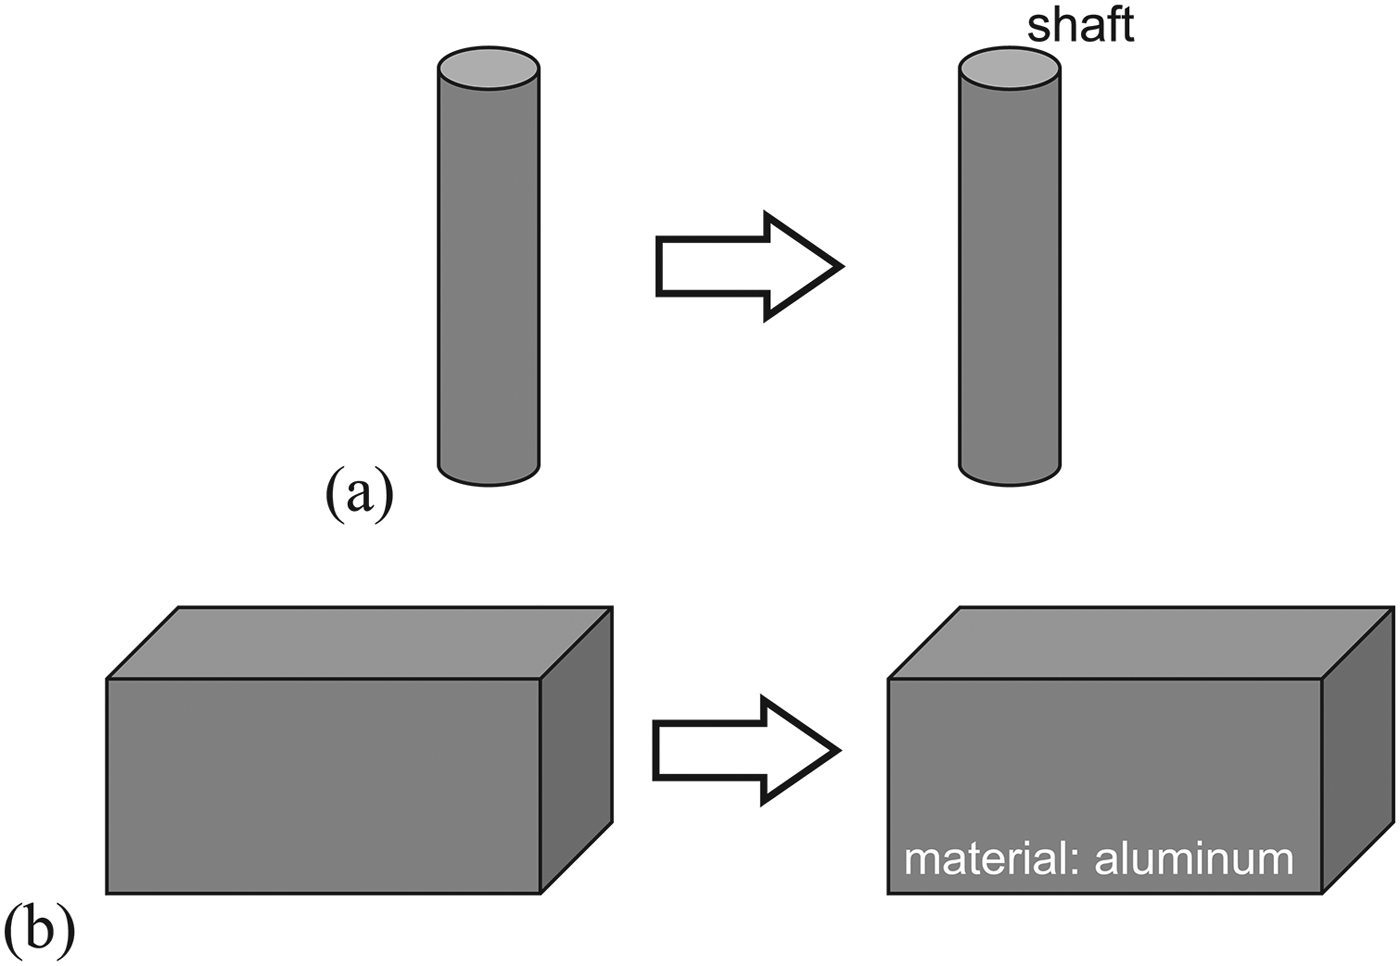
However, labels can also be used to augment shapes with additional, nongeometric information or data. For example, they can distinguish or classify basic elements and parts of shapes, or they may have their own semantics to introduce other kinds of properties (Stiny, Reference Stiny2006). Other examples are the use of text labels for the denotation of shapes, which can also be used to assign semantic or functionality to shapes. In the same way, labels can assign, for example, materials to solids that can be used to calculate the mass or render the texture and color of a solid (Heisserman, Reference Heisserman1994).
For example, rule (a) in Figure 7 adds the textual label “shaft” to a cylinder so that it differs from other cylindrical objects and gives semantic meaning to the geometry. A further rule could be defined that only applies to a “shaft” and no other cylinder. Similarly, rule (b) augments the block with information about its material.
Rules with labels adding nongeometric information to geometry.
The last category of labels shown in Figure 6 is the simplification of the LHS matching of a rule in the CWS. For the computational implementation of grammars, the LHS matching problem is a central challenge (Krishnamurti & Stouffs, Reference Krishnamurti and Stouffs1993), because the computer relies on formal representations of geometry that are not sufficiently suited to detect visual similarity of geometry under Euclidean transformations in a general way. This is especially true for curved shapes (Jowers & Earl, Reference Jowers and Earl2011). In paper-based grammars, matching the LHS in the CWS relies on the human ability to recognize the equality of possibly parametric (sub)shapes under Euclidean transformations. The computational complexity of the matching operations means that the shape grammar formulation of spatial grammars does not lend itself well to computer implementation (Heisserman, Reference Heisserman1994). Set grammars, which the approach presented in Hoisl and Shea (Reference Hoisl and Shea2011) is based on (cf. Section 3.1), are more amenable to computer implementation. Nevertheless, difficulties in the implementation of the LHS matching exist regarding, for example, the calculation of the transformations, recognition of complex geometries, and parametric rules. The latter two issues are especially important to generate meaningful geometry in engineering because in this area shapes are usually not only simple orthogonal lines or blocks (Cagan, Reference Cagan, Antonsson and Cagan2001) and there is a great need for modeling constraints in rules.
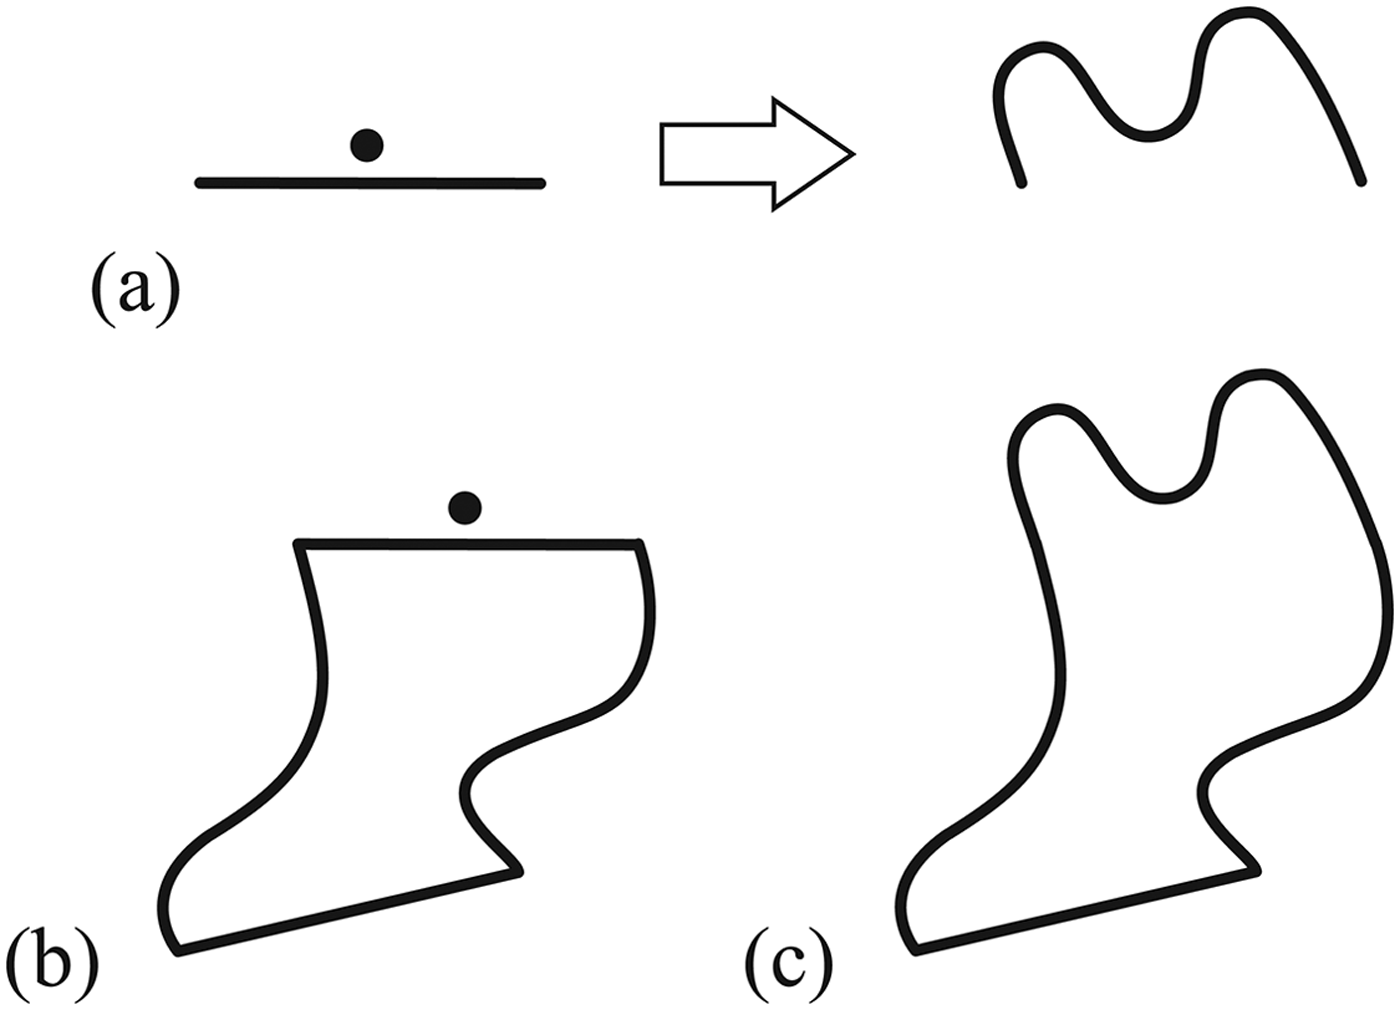
A few examples for spatial grammars exist that, while using curves, avoid shape matching entirely by relying on labels (McCormack & Cagan, Reference McCormack and Cagan2006). In the example in Figure 8, the problem of matching curved geometry is circumvented using a combination of a straight line and a label in the LHS of Rule (a). Instead of having to match curved geometry in the CWS (b), only the label and the straight line have to be matched.
Example using simplified left-hand side matching.
The label in (b) indicates that a further rule has to be applied (i.e., the CWS with the straight line is an intermediate stage). The straight line acts as a reference, because only using the label in the LHS would not depict the rotation under which the rule has to be applied. In general, the reference does not necessarily have to be a line, but multiple options using points and lines are possible to achieve this goal. The application of the rule results in the curvilinear design in (c). It can be seen that this label type is an extension of the spatial label.
2.2.2. Labels in existing spatial grammars
In this section several concrete examples for labels in existing set or shape grammars both on paper and in computer implementations are investigated. The examples show different aspects and uses of labels.
Paper-based grammars
Many spatial grammars using labels exist on paper. One of the early examples is the ice-ray grammar that generates Chinese lattice designs (Stiny, Reference Stiny1977). In this parametric grammar, labels are represented as simple dots and are exclusively used to prevent the application of rules to the same polygon more than once. Knight (Reference Knight1980) presents a grammar for the design of Hepplewhite chair backs that uses different kinds of parametric labels represented, for example, by letters, dots, or star symbols. They are mainly spatial labels because they depict the positions in which lines are added to the CWS, but also rules are used that remove the labels from the CWS to guide the termination of the generation process. A third example is the 3-D kindergarten grammar (Stiny, Reference Stiny1980b). The main purpose of using labels in this grammar is the determination of the transformations under which the LHS of a rule can be matched. The paper discusses many examples of different symmetries of the blocks; the labels, therefore, depict the rotation or reflection transformations.
In the field of architecture, many spatial grammar examples exist that make heavy use of labels (e.g., Downing & Flemming, Reference Downing and Flemming1981; Flemming, Reference Flemming1987; Duarte, Reference Duarte2005). In the grammar developed by Koning and Eizenberg (Reference Koning and Eizenberg1981) for the generation of prairie houses in the style of Frank Lloyd Wright, labels are represented using a range of different letters and symbols. Several of them depict the rule sequence. For example, the generation always starts with the introduction of the fireplace, followed by the living zone, and subsequently adding a service zone. Labels determine the location where rules can be applied and sometimes the transformation under which the new part of the house is added to the CWS. Other labels distinguish the functionality of different parts of the house, which are spatially defined as compositions of rectangular blocks.
Among the more recently published grammars, there are several stemming from the engineering design domain. For example, Pugliese and Cagan (Reference Pugliese and Cagan2002) present a grammar that creates different side views of Harley-Davidson motorcycles, in which labels guide the designer in the selection of the rule sequence. In the Buick grammar (McCormack et al., Reference McCormack, Cagan and Vogel2004) that generates front views of the Buick car, some of the start or end points of curvilinear shapes are labeled with additional information about representing “sharp” or “soft” transitions concerning the continuity of the line flow to the next line segments. The latter two approaches for grammars are merged in the work presented by Orsborn et al. (Reference Orsborn, Cagan, Pawlicki and Smith2006). A rule in this grammar consists of front, side, and rear views of a vehicle arranged next to each other. One and the same label can occur in several views in parallel. The majority of the labels have a spatial and a state label character at the same time. By using a numbering system, they are defined to drive the rule application so that feasible solutions are generated that contain the main characteristics of a vehicle design.
Implemented grammars
The majority of implemented spatial grammars allow for the definition of labels; however, not all do. In comparison to paper-based definitions where the developer of a grammar can draw any kind of symbol to represent a label, labels in computer-based implementations are predefined objects in the system. For the use in implemented systems that allows the user to define new rules, it has to be assured that there is no chance that labels can be recognized by the system as “normal” shapes (i.e., it is necessary that the two sets are disjoint). In some cases, labels are represented using general geometric objects that are then not used in the definition of the shapes in the rules, similar to the original definition in Stiny and Gips (Reference Stiny and Gips1972). For example, in two dimensions a filled circle or in 3-D a cylinder with a certain diameter are often used as the symbols for labels. Internally, it must be clearly defined which geometric objects define shapes and which define labels.
Many of the existing systems were hard-coded for one specific grammar, “meaning that a computer program was created entirely to implement a single set of rules” (McCormack & Cagan, Reference McCormack and Cagan2003). One example is the coffee maker grammar (Agarwal & Cagan, Reference Agarwal and Cagan1998) that makes use of labels to control the generation process. Labels are defined using a wide range of letters and numbers, sometimes in combination with dots, squares, or triangles. Most of these labels have spatial label character determining the location where rules apply. The labels that depict functional entities, such as the filter or the water storage unit of the coffee makers, incorporate state label functionality because they force the generation process to consider a certain subset of rules of the grammar. The implementation of the grammar further relies on labels to circumvent the need to match curvilinear lines (cf. McCormack & Cagan, Reference McCormack and Cagan2006). A similar combination of spatial and state labels is used in an implementation for the application of rules that generate sections of two-dimensional Chinese wood-frame buildings (Li & Kuen, Reference Li and Kuen2004). In many cases the generation of the building geometry terminates even if further labels are existent, but several rules are available to remove remaining labels from the CWS. Another example that uses labels to guide the application process is a grammar for the generation of microelectromechanical devices (Agarwal et al., Reference Agarwal, Cagan and Stiny2000). In this example, labels also help to distinguish between lines representing springs, anchors, actuators, and mass, as well as the inside and the outside of a shape. Using a form–function coupling, labels are used to ensure that some indispensable functional entities exist in any final design solution.
During the last 15 years, an increasing interest in implementing more general spatial grammar systems can be seen. Several of them incorporate the use of labels. In the GEdit system (Tapia, Reference Tapia1999) shape rules can contain labels to restrict the application of rules to a certain shape or to deal with reflection symmetries. They are drawn as ovals that can be filled with different patterns to define a variety of labels. In Shaper2D (McGill & Knight, Reference McGill and Knight2004), labels are used exclusively to remove symmetry of shapes. Their position can be changed to different predefined locations that are dependent on the degrees of the symmetry of a particular shape. Deak et al. (Reference Deak, Rowe, Reed and Gero2006) implemented a system that is based on straight lines. These lines can be distinguished by assigning different line types that can be seen as augmenting labels. Another implementation that is based on straight lines was published by Trescak et al. (Reference Trescak, Esteva and Rodriguez2009) and allows for the definition of dots that are used as spatial labels in rules.
Concerning 3-D systems, Heisserman (Reference Heisserman1994) uses labels to restrict rule application in his Genesis system that was used to generate, for example, alternative Queen Anne houses. Textual labels are also used to introduce nongeometric data (e.g., to distinguish between different kinds of rooms). The 3-D interpreter presented by Piazzalunga and Fitzhorn (Reference Piazzalunga and Fitzhorn1998), which implemented grammars such as the Sierpinski grammar, used labels represented by single letters. The labels are used to restrict the application of rules to a certain geometric object, to remove symmetries, and in some cases to define a certain rule sequence. Spatial and state functionality are sometimes combined in one label. An example for using labels to introduce additional, nongeometric information can be found in Starling and Shea (Reference Starling and Shea2002). The grammar distinguishes structural elements by assigning text labels, for example, “disk,” “spindle,” or “plate” to cylindrical primitives. In 3DShaper (Wang & Duarte, Reference Wang and Duarte2002), labels are defined to eliminate the ambiguity in shape rule applications that arises due to the symmetry of blocks. The position of a label can be set to one of the corners of a specified block. During generation, these labels are not removed. Rules are applied to the most recently added block because the rule sequence is predefined in the way the grammar is implemented and not through guidance from labels. The SGS system by Chau et al. (Reference Chau, Chen, McKay, de Pennington and Gero2004), which allows for the generation of 3-D wireframe models, uses dots in combination with different single letters as labels to restrict rule application to certain parts of the CWS and to remove symmetries. Based on the use of letters, the labels can also be used to realize state labels. The implemented example of a Coca-Cola bottle grammar uses straight lines and labels in the LHSs of the rules to circumvent problems with matching curvilinear lines. The latest prototype implementation of a 3-D grammar system, Grammar Environment (Li, Chau, et al., Reference Li, Chau, Chen and Wang2009; Li, Chen, et al., Reference Li, Chen, Wang and Chau2009), is based on the system by Chau et al. (Reference Chau, Chen, McKay, de Pennington and Gero2004) and provides the same functionality with respect to the use of labels.
3. 3-D LABELS
The concept described in this paper is used to enhance a computer-based approach for the development and application of spatial grammars, which was previously presented by the authors in Hoisl and Shea (Reference Hoisl and Shea2011). The definition of labels for all potential uses, as defined in Figure 6, during rule development is enabled within the spatial grammar interpreter.
In this section, first, the basics of the existing spatial grammar interpreter are briefly described, because they are important for the understanding of the remainder of the paper. Second, the concept of 3-D labels is introduced, and different uses are presented with a focus on simplifying the matching of the LHS of parametric rules that include complex shapes.
3.1. A visual and interactive approach to developing and applying spatial grammars
The approach presented in Hoisl and Shea (Reference Hoisl and Shea2011) provides a flexible platform supporting designers with visual, interactive definition and application of their own grammar rules without programming (Fig. 9). The underlying ideas of this approach are the basis for the label concept presented in this paper. The approach is based on a set grammar formulation of spatial grammars and supports the definition and application of nonparametric and parametric rules. The vocabulary consists of a set of parameterized 3-D primitives, namely, box, torus, cone, cylinder, sphere, and ellipsoid.
(Color online) A screenshot of the prototype software system during the definition of a rule.
For the definition of a rule, a number of primitives are inserted on each side of the rule (i.e., LHS and RHS), and their parameters are specified. The parameters describe the size as well as the location and orientation of the objects. Every primitive geometric object that is created has its own local coordinate system. This coordinate system and, therefore, the attached object itself can be translated and rotated in relation to the global coordinate system. This information is kept in a transformation matrix. A rule is designed such that there is one reference object in the LHS, which is located in the global origin and must not be rotated. Figure 10 provides examples for a nonparametric rule (above) and a parametric rule (below).
(Color online) Examples of (top) a nonparametric rule and (bottom) a parametric rule.
To create parametric rules, one or more of the objects' parameters are “unlocked.” These “free parameters” can be size parameters, like width, length, and radius, but also location parameters defining the translation of an object in the x, y, and z directions or orientation parameters defining the rotation as “yaw, pitch, and roll.” By default, unlocked parameters are completely unrestricted (i.e., any value can be assigned to them). Further, parametric relations in the form of mathematical equations can be defined between free parameters. Another possibility is to restrict the values that are allowed to be assigned to a free parameter to a certain range. In the latest version of the prototype system (see http://sourceforge.net/projects/spapper/), real values can be defined not only as range limits but also as parametric relations. In addition, one of the limits can be kept blank if only a lower or upper bound is required. These mechanisms for defining and restricting free parameters allow for the visual definition of parametric grammar rules in a computational system. As in the original definition of parametric shape grammars (Stiny, Reference Stiny1980a), rule schema can be defined. Using mathematical equations, specific constraints can be incorporated into rules, which is especially important when developing spatial grammar rules for engineering design tasks.
For the application of a rule, automatic matching of the LHS of a rule in a CWS is carried out along with the calculation of the positions and sizes of the objects in the RHS according to the defined parametric relations. The approach for the matching finds all possible matches of the LHS of a rule in the CWS. It starts with detecting the reference object of the LHS using a comparison of the objects' primitive types and an equality check of the size parameters, which may involve the evaluation of free parameters in the case of a parametric rule. If there is more than one object in the LHS, the remaining objects in the LHS are checked for matching in the CWS. The procedure is the same as for matching the reference object, but the spatial relation between each of the objects and the reference object has to be equal to the spatial relation of the objects detected as matches in the CWS. This is checked by calculating and comparing the relative transformation matrices between the involved objects. Finally, one of the found sets of matched objects is selected to be replaced by the RHS of the rule. According to the equation C′ = C – t(A) + t(B) (cf. formalism in Section 2.1), all of the rules are realized as replacement rules (i.e., even in case of additive or subtractive rules, the matched LHS is fully subtracted from the CWS and replaced by the transformed RHS). The new positions of the RHS's objects are calculated based on the detected transformation of the LHS match, including the determination of the values for any free parameters in the case of a parametric rule.
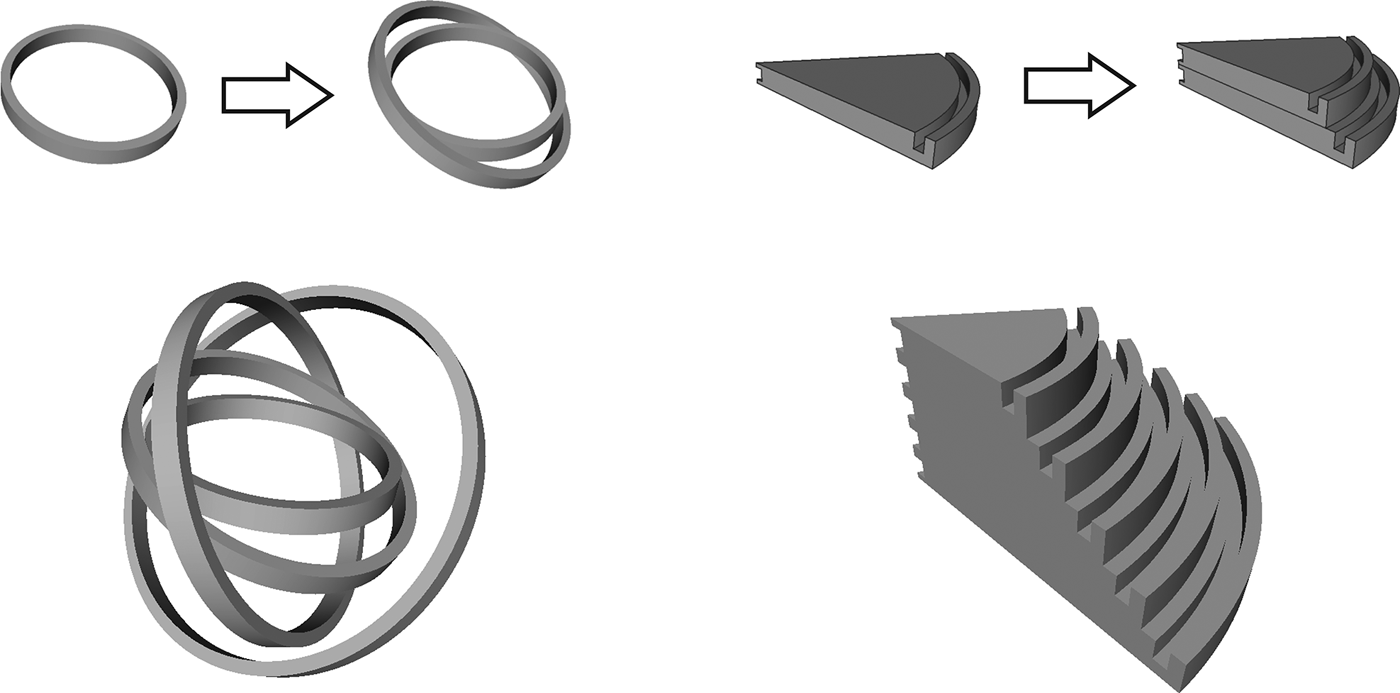
In addition to the approach described by the authors in Hoisl and Shea (Reference Hoisl and Shea2011), the latest version of the prototype implementation, which is based on a computer-aided design (CAD) system, is also able to operate on objects generated using Boolean operations and sweeping operations based on cross sections made up of straight lines (Hoisl, Reference Hoisl2012). Both capabilities extend the complexity of geometric objects that can be used for the definition of parametric rules and, as a consequence, the range of possible designs that can be generated. Figure 11 illustrates one example rule and generated design for each of the two techniques. The “rings” used in the example in the LHS of the figure are created using a Boolean difference operation of two cylinder primitives.
Examples for rules and generated designs using (left) Boolean operations and (right) sweeping operations.
3.2. 3-D labels
The principles described in Section 3.1 are the basis for the enhancement of the approach with a unified label concept for a spatial grammar interpreter. As with the other geometric primitives that can be used in this spatial grammar approach, a label is specified such that it has its own local coordinate system (Fig. 12). This enables the determination of the location of a label using translation transformations. In addition, however, it enriches the label with information about its orientation in 3-D space based on the possibility to change the rotation parameters. Similar to the idea of asymmetric markers (cf. Section 2.2.1), this has an influence on the detection of the transformation required to apply a rule. Because these labels carry information about location and rotation in 3-D space, they are denoted “3-D labels.”
(Color online) A three-dimensional label.
In the approach presented in this paper, labels do not have any geometric properties but only carry transformation information. Hence, it is automatically assured that the set of shapes S and the set of labels L are disjoint. Internally, labels have no solid geometry representation in the underlying CAD kernel, in contrast with the geometric primitives that define the set of shapes S. The sphere that can be seen in Figure 12 only exists for visualization purposes (i.e., it is merely displayed in the graphical user interface to ease the work with labels for the user of the spatial grammar interpreter). Hence, it also cannot be detected as a match of a sphere object by the automatic LHS search during rule application.
Without having any geometric properties, it is not possible to differentiate 3-D labels by means of their shapes. Instead, the approach provides the possibility to assign different colors to a label. The effect is the same as using different shapes. At the same time, it simplifies the automatic matching of a label, because no shape needs to be matched but only the symbolic numbers of the color values. Besides the color, a “label name” can be defined as an additional property. This allows for assigning a letter or a number to further distinguish labels. The label name is not restricted to one single character or number but can consist of a string of arbitrary length and therefore enables the possibility to introduce a wider range of additional information in a grammar rule in textual form. When inserting a new label to a rule, the name is set to the standard name “default” (cf. Fig. 12). It is also possible to erase it and therefore use labels without names as well.
In principle, 3-D labels have the same behavior as any other primitive in the approach. For example, they can be the reference object in the LHS of a rule or define different spatial relations together with other geometric objects. The application, including the matching of several objects and their relative transformations, stays the same as described in Section 3.1. It is also possible to define free parameters, the same way as explained for the definition of parametric grammar rules. Because labels do not have any geometric parameters, only the translation or rotation parameters can be “unlocked.”
A 3-D label is not directly assigned to a shape (i.e., there is no explicit connection defined between the two). Instead, an affiliation can be implicitly given by the spatial relation between a label and a shape. A spatial relation other than the one defined in the LHS of a rule (i.e., a different relative transformation), would not be detected as a match in the CWS.
3.3. General uses for 3-D labels
The concept of 3-D labels introduced in the previous subsection can be used for the common applications of labels as summarized in Figure 6. For use as a spatial label, only the information about the location but not the orientation is relevant. Unlocking all three rotation parameters and making them unrestricted makes a 3-D label a “conventional” spatial label. Using a label in this way, the application of rules can be restricted to a specific part of the CWS, for example, to the most recently added box, as illustrated in Figure 13. This example was previously presented by the authors (Hoisl & Shea, Reference Hoisl and Shea2011) to demonstrate the use of parametric grammar rules. Without labels, it is necessary to manually choose one of the matches to avoid applying the rule to one specific box more than once. Using labels in the definition of the rule (Fig. 13a) enables the automatic generation of the design in Figure 13c. The application starts by matching the LHS of the rule to the initial shape shown in Figure 13b, which contains a randomly oriented 3-D label. It can be matched because the orientation for a spatial label is not important (i.e., the rotation parameters of the label in the LHS of the rule are all unlocked, or free).
(Color online) A three-dimensional label used as a spatial label to restrict rule application to the most recently added shape in the current working shape.
For use as a state label (cf. Fig. 6), in addition to the rotation parameters, the location parameters are set as unrestricted to make the label completely “nonspatial” (i.e., neither the location nor the orientation matter but only that the label exists). The label is then assigned to a rule side rather than to a specific shape. Using 3-D labels as state labels, rules can be defined in a way that the labels implicitly determine the rule application sequence if different kinds of colors and label names are used. In addition, the number of rule iterations or the termination of the shape generation process using a rule that erases the existing label(s) can be controlled. In Figure 14, for example, the rules can only be applied iteratively according to the sequence (a)–(b)–(c) because of the labels. Rule (d) can be used to abort the generation process after three, six, nine, and so on rule applications.
(Color online) Some three-dimensional labels used as state labels.
In comparison to this “internal” guidance for the rule application, the previously presented approach (Hoisl & Shea, Reference Hoisl and Shea2011) provides “external” possibilities to guide the application of rules without the necessity of using state labels. The sequence of rules can be defined in a resortable list of loaded rules. The number of rule applications and therefore also the termination of the generation process can also be explicitly specified. Further, both state labels and the external functionality to guide the application process can be used together.
These 3-D labels can also be used to add nonspatial information to rules (cf. Fig. 6). Developing a new rule, one has to decide whether the additional information is relevant for the LHS matching process during the application of the rule or not. Depending on this choice, the different transformation parameters can be set as unrestricted or restricted. Most important for the augmentation of shapes is the additional “label name.” It can be used to classify or distinguish shapes or to add in a semantic meaning for a shape. The label name can also represent pure textual information that does not have any influence on the rule application but rather remains in the geometric model after design generation is finished. In this regard, such labels can be informative by adding information about design intent and manufacturing, for example, tolerances or welding information, measurement details, materials, texture, and colors.
The last possible use of labels, the simplification of the LHS matching, is discussed in more detail in the next subsection.
3.4. Using 3-D labels for simplified LHS matching
As mentioned at the end of Section 3.1, the latest version of the spatial grammar interpreter enhances the approach described by the authors in Hoisl and Shea (Reference Hoisl and Shea2011) with the possibility to use Boolean operations on objects and simple swept objects for the definition of parametric rules. This is a step toward generating more meaningful geometry for mechanical engineering design tasks. However, solids commonly used in mechanical engineering can be topologically more complex or even derived from free-form surfaces and include a wide range of detailing geometry (e.g., fillets and chamfers). Spatial grammar rules based on such complex geometry are difficult to handle, generally, in an implemented system, especially an interpreter, because of the issues regarding automatic matching of the LHS (cf. Section 2.2.1).
The 3-D label can possibly be used as a ‘substitute’ for geometry in the LHS and therefore circumvent the difficulties with the automatic matching of the LHS. In comparison to the example shown in Figure 8 where the straight line is an implicit reference to determine the orientation under which the RHS of the rule has to be added to the CWS, it is not obligatory to have any shape in the LHS in addition to the 3-D label. This is because the 3-D label, as introduced in the approach in this paper, also carries information about orientation. The abstract additive rules in Figure 15 symbolize the difference between a “conventional” rule (a) and a rule that contains only a 3-D label in the LHS (b). Application of both rules results in the same solution assuming that rule (b) is applied one more time than rule (a).
(Color online) (a) A conventional rule and (b) a rule with only a three-dimensional label on the left-hand side.
For a 3-D label that might exist in the RHS, like the one shown in the example in Figure 15b, a parametric relation can be defined, so that, for example, its location is dependent on an unrestricted parameter of one of the shapes in the RHS. It then implicitly depicts the location of the next rule to be applied in relation to the geometry in the RHS of the currently applied rule.
Rules developed based on this approach can contain an arbitrarily complex, parametric RHS and can be applied as long as the 3-D label in the LHS can be matched.
3.5. Segments
Circumventing the difficulties of the LHS matching with 3-D labels allows for the use of more complex geometry in a spatial grammar. To generate meaningful mechanical engineering parts using 3-D labels for simplified LHS matching, it is necessary that the interfaces between the shapes in the different rules are assured to fit once they are inserted in a design. Shapes with specified interfaces are denoted “segments” in the approach presented in this paper. They are the subparts, or building blocks, used to generate mechanical engineering parts, as symbolically illustrated in Figure 16.
(Color online) Segments and their interfaces used to compose a mechanical engineering part.
This concept has an analogy to an approach often used in variant management, called modular construction or assembly systems (see, e.g., Ulrich, Reference Ulrich1995; or Pahl et al., Reference Pahl, Beitz, Feldhusen and Grote2007). In modular systems, the aim is to define a limited number of basic building blocks, or modules, with well-defined interfaces, so that they can be combined to define a large range of product variants. Often these building blocks are derived from existing, related product variants by extracting their commonalities. The extraction and definition of building blocks from existing designs is also applicable for the definition of segments. Ideally, in modular systems, the parts or subassemblies are used more than once in one product, and the intention with segments in this work is the same (see Fig. 16). In comparison to modular systems that operate on the assembly or product level, the segment concept is used to generate geometric models of parts through a series of interfaced segments. To allow for more complex part compositions, it is useful to define more than one type of interface together with different kinds of labels in the definition of rules.
Three example rules that use 3-D labels in the LHS and segments with complex curved geometry in the RHS are shown in Figure 17a–c. The initial set Figure 17d contains another segment and two 3-D labels. The interfaces of all segments are identical. An example for a solution generated applying the rules is shown in Figure 17e.
(Color online) An example of a spatial grammar using three-dimensional labels and segments.
Because the geometry in the RHS is of no relevance for the further application of rules in a CWS, there are basically no restrictions on how segments are created. CAD systems usually provide many modeling concepts that can be used for designing segments. The most common approach in commercial mechanical engineering CAD systems is feature-based parametric modeling. Features are high-level parametric modeling entities that have some engineering significance and ease the design of recurring shapes (Shah & Mäntylä, Reference Shah and Mäntylä1995). The “standard” features most commonly provided by mechanical engineering CAD systems are fillets, chamfers, pockets, holes, and so forth. A segment can be modeled using different features together with parametric primitives, Boolean objects, or other advanced parametric modeling techniques like sweeps along 3-D trajectories, lofts for the generation of solids, or parametric free-form surfaces, to derive solids. An extended feature concept that is often allocated to the area of knowledge based engineering is user-defined features (UDFs). UDFs enable designers to define their own customized compound features (e.g., see Hoffmann & Joan-Arinyo, Reference Hoffmann and Joan-Arinyo1998). These help to facilitate the design of frequently occurring, similar subparts of geometric models, as needed, for example, in product variants. A UDF can be composed of different standard features and might contain parametric relations and parameters that can be changed to instantiate the geometry of the UDF once it is inserted in a design. In conventional CAD design, the designer has to position the UDF in an existing model and manually define the required reference elements. Using UDFs as segments for the definition of rules with a 3-D label in the LHS enables their automatic addition to an existing design based on the transformation information of the 3-D labels.
4. EXAMPLE: ROBOT ARM CONCEPTS
An example for spatial grammars focusing on simplified LHS matching is created using the prototype spatial grammar interpreter to demonstrate the conceptual application of the approach. The example is able to generate different complex geometry solutions for robot arm concepts. A robot usually consists of several robot arms that can be rotated around different axes. These robot arms have to be designed in a way that they fulfill requirements concerning stability, weight, design space, and so forth. Here, the application is approached only conceptually as an example for complex, 3-D design generation in a mechanical engineering related area. The spatial grammar is intended at this point to illustrate and validate the 3-D label approach rather than validate the grammar itself (i.e., in terms of the design space defined). The grammar rules for this example were derived by analyzing existing industrial robots, for example, the one shown in Figure 18, in terms of part geometry, modularity, and joining of parts to create a complete robot arm assembly.
(Color online) An example of an industrial robot (computer-aided design model).
Figure 19 shows the spatial grammar developed based on the approach of using 3-D labels for representing spatial constraints, state constraints, nongeometric information, and simplified LHS matching of different segments of robot arms. The grammar is not hard coded but rather developed and applied within the spatial grammar interpreter prototype developed by the authors (see http://sourceforge.net/projects/spapper/).
(Color online) Spatial grammar for the generation of robot arm concepts.
Rule (a) is the first rule to be applied. It uses the starting symbol in the LHS to start from the empty shape (i.e., no geometry) and adds a segment consisting of a parametric joint as well as the first part of the robot arm with a specified interface. In addition, a default 3-D label is defined in the RHS so that further rules can be applied. This label serves both as a state label and to simplify the LHS matching through specification of the translation and rotation transformations needed such that the segment added in the RHS is aligned with the previous segment. The radius, r, is defined to be within a range of 30 to 40 mm, so that the diameter of the joint can be adapted (e.g., depending on the load the arm has to resist). The translation, translateY, of the joint depicts the offset of the joint's center from the label and is set depending on the radius. Rules (b)–(e) and (h) can be applied after this first rule because they all have a default label in the LHS. The RHS of rule (b) consists of a bridge segment that extends the length of the robot arm. It is based on an extrusion in the y direction, dirY b, which is restricted to a range between 30 and 100 mm. In addition, it contains a stiffener that is positioned in the middle of the extruded part (translateY s) and can be rotated within a range of ±15° around the x axis (roll s) depending on the main direction of the force application on the robot arm. A second stiffener on the backside of the part is positioned according to the first one. Rule (c) adds another bridge segment that includes a narrowed cross section in the middle. It can help in cases where the weight of the robot arm has to be reduced or the load on the arm is not high. The length of this middle part of the segment is parametric and restricted by a range. Rule (d) allows for extrusions in three different directions, dirX, dirY, and dirZ, that are all restricted to certain ranges. In cases where dirX and dirZ are zero, the rule is identical to rule (a), except with the addition of stiffeners. Application of the rule results in a deviation of the main robot arm direction from the y axis. This can be needed in cases where the available space for the robot arm is restricted, for example, to avoid collisions with other obstacles. Rule (e) is geometrically and parametrically identical to rule (b). The difference is that it introduces a new kind of label that carries a different color and the name “split,” and therefore also changes the state. In addition, not one, but two, of these labels are defined in the RHS of this rule. After applying this rule, none of the previously described rules or rule (h) can be applied, because the default label in the LHSs (i.e., its name and color) can no longer be matched. Instead, only the two rules (f) and (g) are applicable. The first one adds a smaller, nonparametric segment with a different interface, which nonetheless geometrically fits the interface used in the other rules. Application of this rule results in the creation of a cutout in the robot arm. This can help to reduce weight or create space for attachment parts or electrical motors. Repeated application of this rule creates longer holes. When rule (g) is applied, the generation of a hole is terminated. Rule (g) is an abstract rule because it does not result in any geometrical changes but instead substitutes two split labels with a distance of 50 mm to each other by one default label that is positioned in the center of the locations of the two split labels. After rule (g) is applied, the rules with default labels in the LHS can be applied again. To end the generation of a robot arm, a further abstract rule (h) is defined. It substitutes a default label by a “finish” label, again changing the state but also specifying the transformation for the next segment. The finish label is a state label that restricts further application to one of the rules (i)–(l). In addition, no 3-D label exists in the RHSs of these rules, so that the generation process terminates after their application. Rule (i) finishes a robot arm with a joint that is the counterpart to the joint added by rule (a). Instead of a hole, it consists of a shaft in the center. Similarly, rule (j) consists of a shaft with an axis twisted by 90° in comparison to the start joint in rule (a) to allow for the generation of robot arms with different kinematic characteristics. Rule (k) also adds a shaft, but in this case it is axially aligned to the longitudinal direction of the robot arm. The last rule, rule (l), inserts a joint with a hole instead of a shaft in the axial direction of the robot arm. It has a 3-D label in the RHS carrying the nongeometric information that it should only be assembled to a particular axial shaft, that is, only to the joint inserted by rule (k) and not the ones introduced by (i) or (j). The combination of these two parts realizes a joint that can rotate a robot arm around its own longitudinal axis. This is often needed to position the gripper on the top of the robot to reach an intended location.
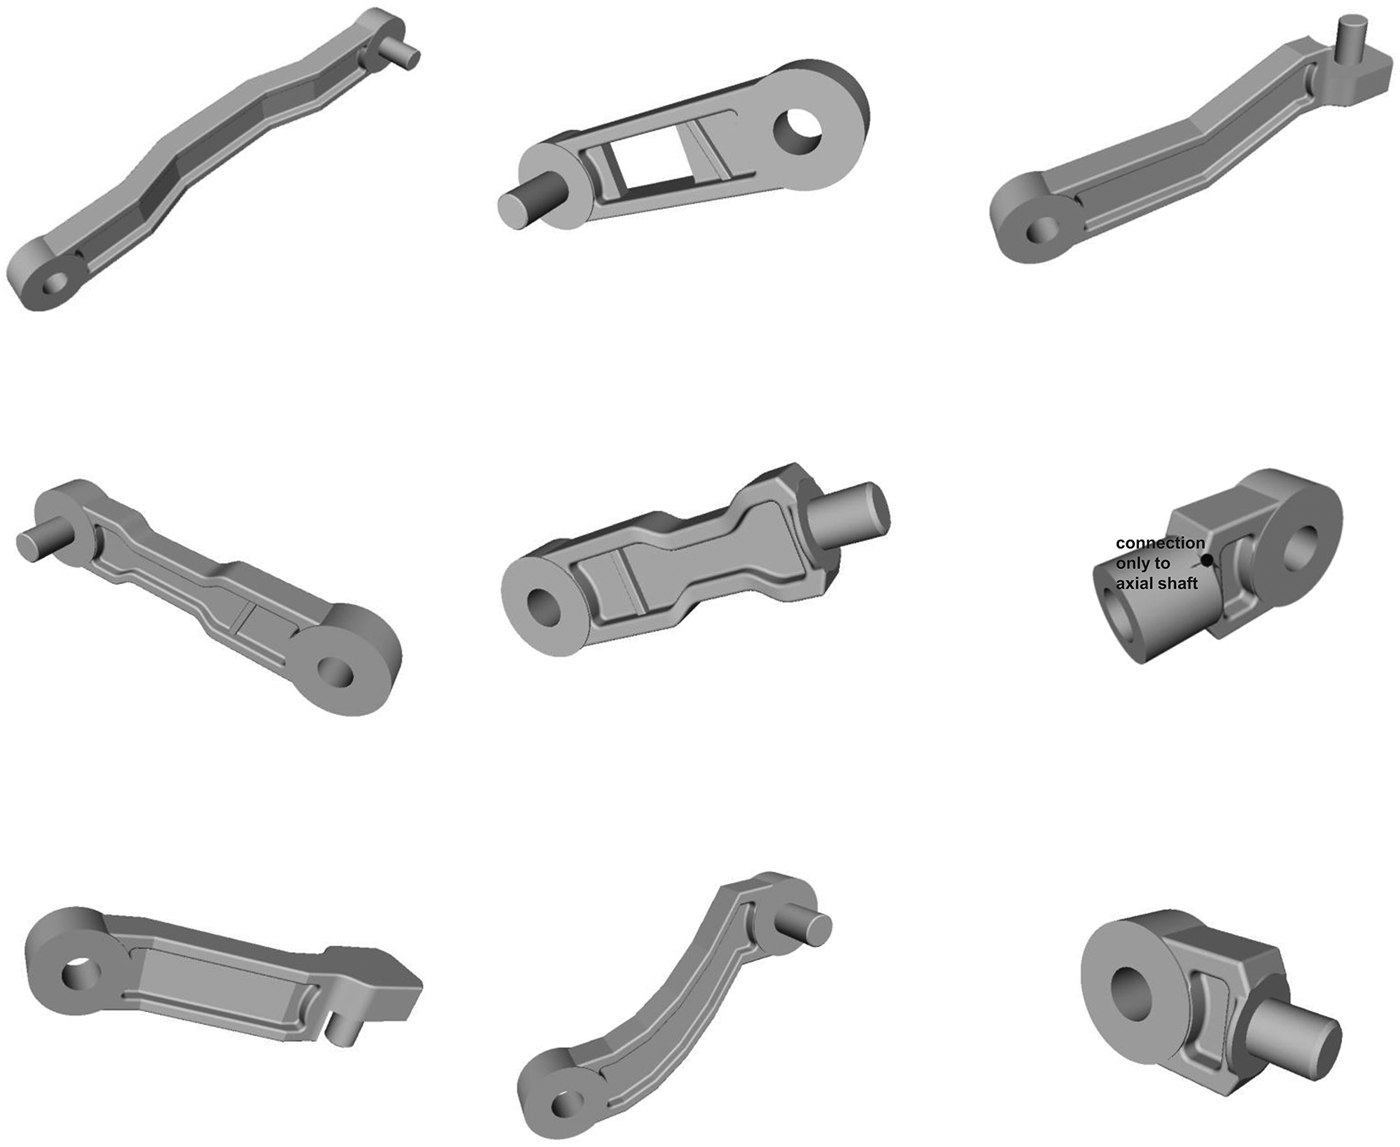
Figure 20 shows a selection of different robot arm link designs generated using the rules defined above. The application of the rules including the LHS matching is performed automatically, where the rule sequence and the concrete values that are assigned to the free parameters are chosen randomly by the system during rule application. The generated examples serve to demonstrate the 3-D label approach and its capability to consolidate all the potential uses for labels in spatial grammars shown in Figure 6 into one concept and a uniform implementation within a spatial grammar interpreter.
Several solutions for robot arm links.
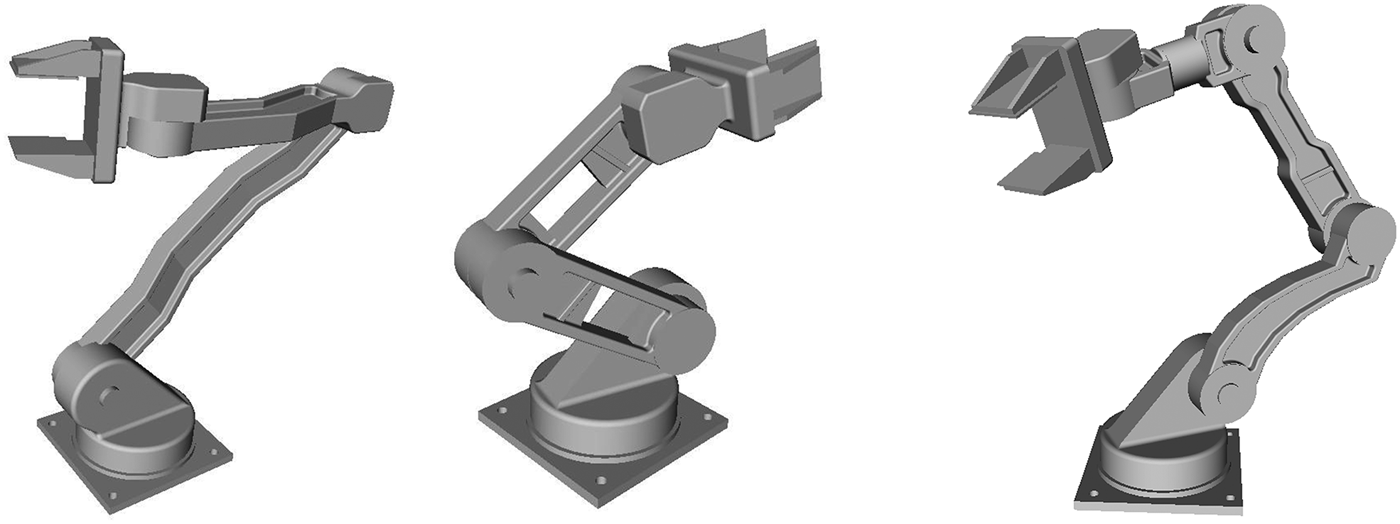
Three examples for manually assembled robot arms are illustrated in Figure 21. The rotary base and the gripper are always identical and therefore designed manually and inserted after design generation.
Examples for robot arms assembled using the concepts shown in Figure 20.
5. DISCUSSION
Carrying translation as well as rotation information and no geometric attributes (i.e., in terms of shape but rather color and name), 3-D labels provide a single, integrated concept that comprises the different common uses of labels in spatial grammars (i.e., as spatial and state labels), adding additional nongeometric information and especially to simplify the LHS matching. In combination with the use of defined “segments,” the latter enables the generation of complex mechanical engineering parts based on parametric spatial grammar rules. The concept introduced in this paper enhances the approach for the spatial grammar interpreter system introduced by the authors previously (Hoisl & Shea, Reference Hoisl and Shea2011) with the addition of 3-D labels.
Several issues with the approach as well as future work are now discussed. First, the concept described does not include an explicit assignment of a label to a shape. A relation between the two is implicitly given by the relative transformation between them. Due to this, the possibility exists that two different shapes in the CWS can have the exact same relative transformation with respect to a single label. Enabling the direct assignment of a label to a shape would enable the user to explicitly decide whether cases like this should be allowed.
Second, 3-D labels do not have any geometric parameters, but their translation and rotation parameters can be used for the definition of parametric spatial relations. The remaining parameters, color and name, can only be set and matched statically. Making colors and label names also available as parametric properties would enable a generalization with regard to matching a wider range of labels. For example, the color of a label could be restricted by a range of colors, where the upper and lower limits are defined by certain color values. Using numbers as label names would further allow for the definition of equations. Assume, for example, that the match of a rule's LHS delivers a label with name “2” and the currently applied rule contains an equation adding “3” to the detected name. This would mean that the next rule that can be applied would have to contain a label with name “5” in its LHS. This opens up further possibilities, especially with regard to state labels. On an even more general level, the use of regular expressions could be considered to match not only numbers but also strings and substrings.
Third, using 3-D labels for the simplification of the LHS matching enables the creation of more complex geometry. However, there are also some limitations and drawbacks to this concept. It requires the grammar rule developer to put more effort in the design of the interfaces of the different segments, because it has to be assured that they fit together to create meaningful designs. If the interface geometry could be automatically detected, the interface of the segment in the RHS of a rule could be parametrically adapted. Another disadvantage is that only the RHS of a rule can be parametric with regard to geometry. Because no geometric objects are defined in the LHS currently, only parametric relations between the locations and/or orientations of 3-D labels can exist. The biggest limitation of the concept of using 3-D labels for the simplification of the LHS matching, however, is that only rules that add geometry to a CWS can be defined. While the rule application of the overall spatial grammar approach internally works on the basis of subtracting the LHS from the CWS and then adding the RHS, which also applies to the labels, a geometrically complex segment, once it is inserted into a CWS, cannot be removed by another rule because rules only contain labels in their LHS.
In future work, further examples using the 3-D labels approach to circumvent the LHS matching problem could be developed using other, more advanced 3-D modeling techniques for the design of parametric segments. Especially UDFs are interesting for further investigation because they have the potential to be used in the LHS of a rule as parameterized geometry to enable the definition of more complex parametric, subtractive, and replacement rules. A further issue for investigation is using the 3-D labels concept not only on the part level but also for the assembly of several generated part designs into a complete product. This has the potential to create complete product architectures with different, customized part geometry generated from scratch based on rules.
Taking a longer term perspective, alternative possibilities for not only circumventing but also resolving the LHS matching problem need to be investigated to overcome the limitations discussed. It may be promising to investigate the incorporation of more general existing 3-D shape search methods that are based on the comparison of, for example, voxels and boundary representations (see, e.g., Iyer et al., Reference Iyer, Jayanti, Lou, Kalyanaraman and Ramani2005). Concepts stemming from tools to compare 3-D CAD models could also prove helpful because they provide the possibility to compare very complex solids.
Considering the overall goal to create a general, spatial grammar interpreter for mechanical engineering design problems, it is important to provide an interface to simulation to evaluate and optimize generated designs according to engineering requirements (e.g., strength, kinematics, weight, cost, or number of parts). Finally, with regard to downstream processes like manufacturing, the spatial grammar approach can also be combined with automated machining planning approaches to completely automate the design-to-fabrication process for customized products (see, e.g., Shea et al., Reference Shea, Ertelt, Gmeiner and Ameri2010, or Brown & Cagan, Reference Brown and Cagan1997), and it can be investigated to what extent labels can be used to encode fabrication information.
6. CONCLUSION
Spatial grammars have been successfully applied in a variety of domains to describe languages of shapes and generate alternative designs. The original formalism includes labels that have been used in existing spatial grammars in various manners, especially to restrict rule application. This paper introduces 3-D labels that integrate and unify the different uses of labels in a single concept. These 3-D labels carry information about not only their location but also their orientation in 3-D space. Therefore, they can be used to add spatial, process state, and nongeometric information to rules as well as circumvent the LHS matching problem. This approach enables the use of more complex geometry in parametric spatial grammar rules. The implementation of the concept, demonstrated through several abstract examples as well as generation of robot arm concepts, enhances the capabilities of the spatial grammar interpreter system that was previously presented by the authors (Hoisl & Shea, Reference Hoisl and Shea2011) and now enables the visual definition of 3-D labels in rules to enable the generation of more complex shapes, parts, and assemblies. This extension in combination with the segment approach introduced in this paper enhances the potential application in mechanical design where parts and products (e.g., robot arms as shown in this paper) often consist of an assembly of complex geometric parts.
ACKNOWLEDGMENT
The authors gratefully acknowledge the support of the Graduate School's Thematic Graduate Center SFB 768 at Technische Universität München.
Frank Hoisl received his PhD in mechanical engineering, specializing in virtual product development, from the Technische Universität München in 2012, where he worked as part of the Virtual Product Development Group within the Institute of Product Development. Dr. Hoisl currently works in engineering CAD management in the automotive industry.
Kristina Shea is a Professor of engineering design and computing at ETH Zurich. She studied mechanical engineering at Carnegie Mellon University, where she completed her PhD in 1997. She has held appointments as a postdoctoral researcher at EPFL, Switzerland; a university lecturer at University of Cambridge; and a professor at Technische Universität München. Dr. Shea's research interests are in new computational models, methods, and tools for design with a focus on supporting early stage design including synthesis, optimization, and fabrication. She is specifically interested in formal, integrated product models, graph and shape grammars, multiobjective and multidisciplinary optimization, and development of cognitive products and cognitive fabrication systems.