



1. Introduction
Research has shown that there are rich mineral resources in the ocean, which takes up three-quarters of the Earth's surface. The exploration of the vast ocean has become a momentous issue for humans. Underwater navigation technology, as the core technology of ocean exploration, is the most difficult challenge to tackle (Zhang et al., Reference Xu, Shen, Chen, Bu and Feng2019). In the domain of underwater navigation, the strapdown inertial navigation system (SINS), with the performance characteristics of high autonomy and anti-interference, is widely utilised. But SINS has some performance deficiencies (e.g. unbounded position error growth and position/velocity/attitude Schuler oscillations). In light of this, acoustic positioning system, Doppler velocity log (DVL), Global Position System (GPS), depthmeter, and terrain matching are commonly introduced as alternatives to provide navigation information for underwater vehicles (González-García et al., Reference Gao, Li, Zhou and Li2020). Among these, DVL has become one of the main auxiliary navigation devices in underwater navigation by virtue of its reliability, autonomy and convenience. Recently, the SINS/DVL integrated system has developed into a reliable and important navigation system in underwater navigation (Yao et al., Reference Wang2019).
The errors of the SINS/DVL integrated system can be categorised into inertial measurement unit (IMU) errors and DVL errors. The IMU is composed of three gyroscopes and three accelerometers to provide angular velocity and specific force measurements (Sabet et al., Reference Narasimhappa, Mahindrakar, Guizilini, Terra and Sabat2018). The DVL is a device with four identical energy converters to output velocity information (Tal et al., Reference Raman2017). Both are subject to scale factor, misalignment error, and random error. The fixed scale factor and misalignment error can be estimated in the calibration process. However, the random error of the IMU, sensitively influenced by temperature, pressure, and mechanical stresses, cannot be calculated in advance. To address this problem, a Kalman filter (KF) is introduced to estimate the random error of the IMU while blending the navigation information from the SINS and DVL (Narasimhappa et al., Reference Narasimhappa, Mahindrakar, Guizilini, Terra and Sabat2016, Reference Liu, Fan, Lv, Wu, Li and Ding2020; Eliav and Klein, Reference Eliav and Klein2018; Hu et al., Reference Hu, Gao, Zhong, Ni and Gu2018).
The optimality of KF relies on the correct prior knowledge of the process noise covariance matrix Q and the measurements noise covariance R (Mohamed and Schwarz, Reference Lee, Lee, Hong, Kim and Seong1999). The matrix Q is often regarded as constant because the process noise in the navigation process is relatively invariable. Nevertheless, due to the complex underwater environment, such as ocean currents, marine organisms, changeable temperature and salinity, the random error of the DVL is variable and unpredicted. The affiliated matrix R is inconsistent with the reality and it will result in substantial estimation errors or even filter divergence. To solve this, two methods are proposed. One is the pure SINS method, which abandons the DVL information in cases where there is too much noise from the DVL. But then navigation errors accumulate quickly with time. The other is the adaptive KF (AKF) method, which estimates the statistical characteristics of the process and measurement noise to attenuate errors (Raman, Reference Mohamed and Schwarz1972; Hu et al., Reference Hu, Gao, Zhong, Ni and Gu2020).
Since its inception, the use of AKF has become widespread in integrated navigation systems. Xu et al. researched the use of AKF in the USBL/INS integrated system (Xu et al., Reference Sage and Husa2018). Liu et al. innovated an improved AKF for the INS/GPS integrated system of autonomous vehicles (Liu et al., Reference Jin, Guo, He and Guo2018). Zhang et al. applied AKF to position correction based large depth navigation for autonomous underwater vehicles (AUV) (Zhang et al., Reference Zhang, Tang, Qin and Wang2020). This paper focuses on the application of AKF in the SINS/DVL integrated navigation system.
The AKF can be divided into four categories: Bayesian, maximum likelihood, correlation, and covariance matching. Each of them is based on the Bayes theorem and can be regarded as a particular form of Bayesian estimation. Based on the Bayesian estimation, a variational Bayesian based KF was proposed and successfully applied to INS/GPS integrated navigation (Huang and Zhang, Reference Hu, Ni, Gao, Zhu, Wang and Zhong2017; Yulong et al., Reference Xu, Liu, Ding, Lv, Feng, He and Yan2018). However, because of the high computational complexity, it is not widely used in underwater navigation. Based on the maximum likelihood principle, a novel adaptive unscented KF combining the maximum likelihood principle with moving horizon estimation was developed (Gao et al., Reference Gao, Li, Zhou and Li2017). The correlation method is based on the correlation of the output either directly or after a known linear operation. A correlation method based KF with nonlinear models was researched (Yang et al., Reference Yang and Xu2018). To make the theoretical covariance consistent with the residual, covariance matching estimation is prevalent in integrated navigation systems by virtue of its simplicity of calculation and high accuracy (Jin et al., Reference Hu, Wang, Zhong, Gao and Gu2017).
As a covariance matching estimation strategy, the Sage–Husa AKF (SHAKF) was proposed and has become widely utilised (Sage and Husa, Reference Narasimhappa, Mahindrakar, Guizilini, Terra and Sabat1969; Liu et al., Reference Liu, Fan, Lv, Wu, Li and Ding2019). It estimates the real-time measurement noise covariance by the statistical information of historical epochs. According to the estimation theory, there are two kinds of measurement noise estimations: innovation adaptive estimation (IAE) and residual adaptive estimation (RAE) (Wang, Reference Sabet, Mohammadi Daniali, Fathi and Alizadeh1999). In IAE the measurement noise is estimated by the average of innovations, in RAE it is calculated by the average of residuals. Almagbile et al. proved that with the same filter performance RAE is more reliable than IAE (Almagbile et al., Reference Almagbile, Wang and Ding2010). To simplify computation and improve estimation accuracy, the moving windows (MW) method was proposed to estimate Q and R (Yang and Xu, Reference Tal, Klein and Katz2003), and the exponential weighted moving average (EWMA) method was also introduced (Narasimhappa et al., Reference Liu, Zhao, Sun, Wu, Zhu and Zhang2018; Franzen and Fingscheidt, Reference Franzen and Fingscheidt2019; Xu et al., Reference Sun, Xu, Liu, Zhang and Li2019). However, the optimal window width in MW and the forgetting factor in EWMA have to be determined empirically. Meanwhile, the fact that window width and forgetting factor cannot adapt to a dynamic environment results in unsatisfactory noise estimation performance.
Therefore, an improved EWMA (IEWMA) method for measurement noise estimation is proposed in this paper. An estimation convergence criterion based forgetting factor is improved to adapt to the environment. Compared with the MW and EWMA methods, the IEWMA method can be applied to engineering practice without multiple experiences and the estimation results are more accurate.
The structure of this paper is as follows. In section 2, a SINS/DVL integrated system is designed. In section 3, the IAE and RAE based AKF methods are specifically illustrated, and MW, EWMA and the forgetting factor based IEWMA are presented. In section 4, the results of comprehensive simulation and vehicle tests conducted in this study are presented to illustrate the superiority of the proposed IEWMA method. Section 5 is devoted to the conclusion.
2. SINS/DVL integrated system
In the SINS/DVL integrated system, the loosely coupled method is frequently utilised. This is because the information provided by DVL is generally the velocity information rather than the original information of the four acoustic channels. The diagram of the SINS/DVL integrated system is shown in Figure 1. The KF fuses the navigation information from the SINS with the velocity from the DVL and then updates the navigation errors to correct the navigation results. In addition, the gyroscope errors, accelerometer errors, and DVL scale factor can also be estimated as a part of the state vector. To cast the integrated process in the KF framework, the state equation and measurement equation are established by the time rate differential equations of SINS and the velocity difference of SINS and DVL in the body frame.
Diagram of SINS/DVL integrated system

2.1. State equation
The state equation is established as follows:
 \begin{equation}\boldsymbol{X^{\prime}} = \boldsymbol{FX} + \boldsymbol{GW}\end{equation}
where  $\boldsymbol{X}$ is the state vector,
 $\boldsymbol{F}$ is the state transition matrix,
 $\boldsymbol{G}$ is the system noise matrix and
 $\boldsymbol{W}$ is the process noise vector. The state vector
 $\boldsymbol{X}$ is defined as (Hu et al., Reference González-García, Gómez-Espinosa, Cuan-Urquizo, García-Valdovinos, Salgado-Jiménez and Cabello2019):
 \begin{equation}\begin{array}{ccccc} \boldsymbol{X} & =\left[ {\begin{array}{* {20}{l}} {{\phi_x}}&{{\phi_y}}&{{\phi_z}}&{\delta V_E^n}&{\delta V_N^n}&{\delta V_U^n}&{\delta \lambda }&{\delta L}&{\delta h}&{{\varepsilon_x}} \end{array}} \right.\\ & {\left. {\begin{array}{* {20}{l}} {{\varepsilon_y}}&{{\varepsilon_z}}&{{\mathrm{\nabla }_x}}&{{\mathrm{\nabla }_y}}&{{\mathrm{\nabla }_z}}&{{K_d}} \end{array}} \right]^{^T}} \end{array}\end{equation}
where  ${K_d}$ is the DVL scale factor, and the matrix
 $\boldsymbol{F}$,
 $\boldsymbol{G}$, and
 $\boldsymbol{W}$ are expressed as follows:
 \begin{equation}\boldsymbol{F} = \left[ {\begin{array}{* {20}{c}} {{\boldsymbol{F}_{aa}}}&{{\boldsymbol{F}_{av}}}&{{\boldsymbol{F}_{ap}}}&{ - \boldsymbol{C}_b^n}&{{\boldsymbol{0}_{3 \times 3}}}&{}\\ {{\boldsymbol{F}_{va}}}&{{\boldsymbol{F}_{vv}}}&{{\boldsymbol{F}_{vp}}}&{{\boldsymbol{0}_{3 \times 3}}}&{\boldsymbol{C}_b^n}&{{\boldsymbol{0}_{9 \times 1}}}\\ {{\boldsymbol{0}_{3 \times 3}}}&{{\boldsymbol{F}_{pv}}}&{{\boldsymbol{F}_{pp}}}&{\boldsymbol{C}_b^n}&{{\boldsymbol{0}_{3 \times 3}}}&{}\\ {}&{}&{{\boldsymbol{0}_{7 \times 15}}}&{}&{}&{} \end{array}} \right],\;\boldsymbol{G} = \left[ {\begin{array}{* {20}{c}} { - \boldsymbol{C}_b^n}&{{\boldsymbol{0}_{3 \times 3}}}\\ {{\boldsymbol{0}_{3 \times 3}}}&{\boldsymbol{C}_b^n}\\ {{\boldsymbol{0}_{1\textrm{0} \times \textrm{3}}}}&{{\boldsymbol{0}_{1\textrm{0} \times \textrm{3}}}} \end{array}} \right],\;\boldsymbol{W} = \left[ {\begin{array}{* {20}{c}} {\boldsymbol{w}_g^b}\\ {\boldsymbol{w}_a^b} \end{array}} \right]\end{equation}
where 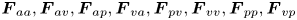 ${\boldsymbol{F}_{aa}},{\boldsymbol{F}_{av}},{\boldsymbol{F}_{ap}},{\boldsymbol{F}_{va}},{\boldsymbol{F}_{pv}},{\boldsymbol{F}_{vv}},{\boldsymbol{F}_{pp}},{\boldsymbol{F}_{vp}}$ are determined by the error equation of SINS,
 $\boldsymbol{C}_b^n$ is the transfer matrix from frame b to frame n, and
 $\boldsymbol{w}_g^b$and
 $\boldsymbol{w}_a^b$ are the error of gyroscope and accelerometer, respectively.
2.2. Measurement equation
The measurement equation is modelled as follows (Lee et al., Reference Huang and Zhang2005):
 \begin{equation}\boldsymbol{Z} = {\hat{\boldsymbol{V}}_b} - {\boldsymbol{V}_{bDVL}}= \boldsymbol{HX} + \boldsymbol{V}\end{equation}
where  $\boldsymbol{Z}$ is the measured matrix,
 ${\hat{\boldsymbol{V}}_b}$ is the velocity calculated by SINS in the body frame,
 ${\boldsymbol{V}_{bDVL}}$ is the velocity provided by DVL,
 $\boldsymbol{H}$ is the measurement transfer matrix and
 $\boldsymbol{V}$ is the measurement information noise. The measurement transfer matrix is:
 \begin{equation}\boldsymbol{H} = \left[ {\begin{array}{* {20}{c}} {\begin{array}{* {20}{c}} {{\boldsymbol{C}_{31}}{V_N} - {\boldsymbol{C}_{21}}{V_U}}&{{\boldsymbol{C}_{11}}{V_U} - {\boldsymbol{C}_{31}}{V_E}}&{{\boldsymbol{C}_{21}}{V_E} - {\boldsymbol{C}_{11}}{V_N}}\\ {{\boldsymbol{C}_{32}}{V_N} - {\boldsymbol{C}_{22}}{V_U}}&{{\boldsymbol{C}_{12}}{V_U} - {\boldsymbol{C}_{32}}{V_E}}&{{\boldsymbol{C}_{22}}{V_E} - {\boldsymbol{C}_{12}}{V_N}}\\ {{\boldsymbol{C}_{33}}{V_N} - {\boldsymbol{C}_{23}}{V_U}}&{{\boldsymbol{C}_{13}}{V_U} - {\boldsymbol{C}_{33}}{V_E}}&{{\boldsymbol{C}_{23}}{V_E} - {\boldsymbol{C}_{13}}{V_N}} \end{array}}&{\boldsymbol{C}_n^b}&{{\boldsymbol{0}_{\textrm{3} \times \textrm{9}}}}&{\begin{array}{* {20}{c}} { - {V_{x\_bDVL}}}\\ { - {V_{y\_bDVL}}}\\ { - {V_{z\_bDVL}}} \end{array}} \end{array}} \right]\end{equation}
3. AKF
Theoretically, the success of the SINS/DVL integrated navigation system strongly depends on the precision of the measurement noise estimation. In this sense, IAE and RAE are proposed for measurement noise estimation by the average of the innovations and residuals over all epochs. However, the historical statistical information may lead to sluggish and biased noise estimation. To solve this problem, two methods are commonly employed. The MW method calculates the average of the innovation or residual information nearing the current epoch in the moving window. The EWMA method calculates the exponential weighted average of the innovation or residual information. However, inappropriate window width of MW and the forgetting factor of EWMA in the dynamic environment may result in undesirable navigation errors. The optimal window width and the forgetting factor have to be determined empirically. Hence, a more reliable method remains to be elucidated. To best of our knowledge, the fixed forgetting factor in EWMA represents the oblivion speed of the historical sequence. In order to improve the noise estimation accuracy, the oblivion speed needs to be adapted to the underwater environment. Therefore, an adaptive forgetting factor based IEWMA method for measurement noise estimation in the INS/DVL integrated system is proposed in this paper.
3.1. AKF with noise measurement estimator based on IAE and RAE
First, the dynamic system is modelled as:
 \begin{equation}\left\{ \begin{array}{l} {\boldsymbol{X}_k} = {{\bf \Phi }_{k,k - 1}}{\boldsymbol{X}_{k - 1}} + {{\bf \Gamma }_{k - 1}}{\boldsymbol{W}_{k - 1}}\\ {\boldsymbol{Z}_k} = {\boldsymbol{H}_k}{\boldsymbol{X}_k} + {\boldsymbol{V}_k} \end{array} \right.\end{equation}
where  ${\boldsymbol{X}_k}$ is the state vector,
 ${{\bf \Phi }_{k,k - 1}}$ is the one-step transfer matrix from epoch k-1 to k,
 ${{\bf \Gamma }_{k - 1}}$ is the system noise matrix,
 ${\boldsymbol{W}_{k - 1}}$ is the system noise,
 ${\boldsymbol{Z}_k}$ is the measurement vector,
 ${\boldsymbol{H}_k}$ is the measurement matrix, and
 ${\boldsymbol{V}_k}$ is the measurement noise.
 ${\boldsymbol{W}_{k - 1}}$ and
 ${\boldsymbol{V}_k}$ are supposed to be uncorrelated zero-mean Gaussian white noise sequences with the statistical characteristics:
 \begin{equation}\left\{ \begin{array}{l} E[{{\boldsymbol{W}_k}} ]= {\boldsymbol{q}_k},Cov[{{\boldsymbol{W}_k},{\boldsymbol{W}_j}} ]= {\boldsymbol{Q}_k}{\boldsymbol{\delta }_{kj}}\\ E[{{\boldsymbol{V}_k}} ]= {\boldsymbol{r}_k},Cov[{{\boldsymbol{V}_k},{\boldsymbol{V}_j}} ]= {\boldsymbol{R}_k}{\boldsymbol{\delta }_{kj}}\\ Cov[{{\boldsymbol{W}_k},{\boldsymbol{V}_j}} ]= 0 \end{array} \right.\end{equation}
where  ${\boldsymbol{q}_k}$ is the mean of the process noise,
 ${\boldsymbol{Q}_k}$ is the covariance of the process noise,
 ${\boldsymbol{r}_k}$ is the mean of the measurement noise,
 ${\boldsymbol{R}_k}$ is the covariance of the measurement noise and
 ${\boldsymbol{\delta }_{kj}}$ is the Kronecker data function. The conventional KF is described as follows:
 \begin{align}{\boldsymbol{X}_{k,k - 1}} &= {{\bf \Phi }_{k - 1}}{\hat{\boldsymbol{X}}_{k - 1}}\end{align}
 \begin{align}{\boldsymbol{P}_{k,k - 1}} &= {{\bf \Phi }_{k - 1}}{\boldsymbol{P}_{k - 1}}{\bf \Phi }_{k - 1}^T + {{\bf \Gamma }_{k - 1}}{\boldsymbol{Q}_{k - 1}}{\bf \Gamma }_{k - 1}^T\end{align}
 \begin{align}{\boldsymbol{K}_k} &= {\boldsymbol{P}_{k,k - 1}}{\textbf{H}}_k^T{({{{\textbf{H}}_k}{\boldsymbol{P}_{k,k - 1}}{\textbf{H}}_k^T + {\boldsymbol{R}_k}} )^{ - 1}}\end{align}
 \begin{align}{\hat{\boldsymbol{X}}_k} &= {\hat{\boldsymbol{X}}_{k,k - 1}} + {\boldsymbol{K}_k}({{{\bf Z}_k} - {\boldsymbol{H}_k}{{\hat{\boldsymbol{X}}}_{k,k - 1}}} )\end{align}
 \begin{align}{\boldsymbol{P}_k} &= ({\boldsymbol{I} - {\boldsymbol{K}_k}{\boldsymbol{H}_k}} ){\boldsymbol{P}_{k,k - 1}}\end{align}
where  ${\boldsymbol{X}_{k,k - 1}}$ is the predicted state estimate,
 ${\boldsymbol{P}_{k,k - 1}}$ is the predicted estimate covariance,
 ${\boldsymbol{P}_k}$ is the updated estimate covariance and
 ${\boldsymbol{K}_k}$ is the Kalman gain matrix.
3.1.1. AKF with noise measurement estimator based on IAE
An AKF with measurement noise estimator based on IAE can be driven as follows:
Defining the innovation as:
 \begin{equation}{\boldsymbol{\varepsilon }_k} = {\boldsymbol{Z}_k} - {\boldsymbol{H}_k}{\hat{\boldsymbol{X}}_{k,k - 1}}\end{equation}
Using Equation (3.1), it can be directly driven that,
 \begin{equation}{\boldsymbol{\varepsilon }_k} = {\boldsymbol{H}_k}{\boldsymbol{X}_k} + {\boldsymbol{v}_k} - {\boldsymbol{H}_k}{\hat{\boldsymbol{X}}_{k,k - 1}} = {\boldsymbol{H}_k}({{\boldsymbol{X}_k} - {{\hat{\boldsymbol{X}}}_{k,k - 1}}} )+ {\boldsymbol{v}_k}\end{equation}
Calculating the covariance of innovation:
 \begin{align} E({\boldsymbol{\varepsilon }_k}{\boldsymbol{\varepsilon }_k}^T) & = E\Big\{{ {\Big\{{{\boldsymbol{H}_k}({{\boldsymbol{X}_k} - {{{\hat{X}}}_{k,k - 1}}} )+ {{v}_k}} \Big\}{{\Big\{{{{H}_k}\Big({{{X}_k} - {{{\hat{X}}}_{k,k - 1}}} \Big)+ {{v}_k}} \Big\}}^T}} \Big\}} \notag\\ & = E\Big\{{{{H}_k}\Big({{{X}_k} - {{{\hat{X}}}_{k,k - 1}}} \Big){{\Big({{{X}_k} - {{{\hat{X}}}_{k,k - 1}}} \Big)}^T}{{H}_k}^T + {{v}_k}{{v}_k}^T} \Big\}\notag\\ & = E\Big\{{{{H}_k}\Big({{{X}_k} - {{{\hat{X}}}_{k,k - 1}}} \Big){{\Big({{{X}_k} - {{{\hat{X}}}_{k,k - 1}}} \Big)}^T}{{H}_k}^T} \Big\}+ E\{{{{v}_k}{{v}_k}^T} \}\notag\\ & = {{H}_k}{{P}_{k,k - 1}}{{H}_k}^T + {{R}_k} \end{align}
Accordingly, the covariance of measurement noise can be described as:
 \begin{equation}{{R}_k} = E({{\varepsilon }_k}{{\varepsilon }_k}^T) - {{H}_k}{{P}_{k,k - 1}}{{H}_k}^T\textrm{ = }\frac{\textrm{1}}{k}\sum\limits_{i = 1}^k {\Big\{{{{\varepsilon }_i}{{\varepsilon }_i}^T} \Big\}} - {{H}_k}{{P}_{k,k - 1}}{{H}_k}^T\end{equation}
3.1.2. AKF with noise measurement estimator based on RAE
An AKF with measurement noise estimator based on RAE can be driven as follows:
Defining the residual as:
 \begin{equation}{{\gamma }_k} = {\boldsymbol{Z}_k} - {\boldsymbol{H}_k}{\hat{\boldsymbol{X}}_k}\end{equation}
Using Equations (3.6) and (3.8), it can be directly obtained that,
 \begin{equation}{\boldsymbol{\gamma }_k} = {\boldsymbol{Z}_k} - {\boldsymbol{H}_k}({\boldsymbol{\mathord{\buildrel{\lower3pt\hbox{$\scriptscriptstyle\frown$}} \over X} }_{k,k - 1}} + {\boldsymbol{K}_k}{\boldsymbol{\varepsilon }_k}) = {\boldsymbol{Z}_k} - {\boldsymbol{H}_k}{\boldsymbol{\mathord{\buildrel{\lower3pt\hbox{$\scriptscriptstyle\frown$}} \over X} }_{k,k - 1}} - {\boldsymbol{H}_k}{\boldsymbol{K}_k}{\boldsymbol{\varepsilon }_k} = (\boldsymbol{I} - {\boldsymbol{H}_k}{\boldsymbol{K}_k}){\boldsymbol{\varepsilon }_k}\end{equation}
Calculating the covariance of residual by the error propagation law (Wang, Reference Sabet, Mohammadi Daniali, Fathi and Alizadeh1999):
 \begin{equation}E({{\gamma }_k}{{\gamma }_k}^T) = {{R}_k} - {{H}_k}{{P}_k}{{H}_k}^T\end{equation}
Accordingly, the covariance of measurement noise can be described as:
 \begin{equation}{{R}_k} = E({{\gamma }_k}{{\gamma }_k}^T) + {{H}_k}{{P}_k}{{H}_k}^T = \frac{\textrm{1}}{k}\sum\limits_{i = 1}^k {\Big\{{{{\gamma }_i}{{\gamma }_i}^T} \Big\}} + {{H}_k}{{P}_k}{{H}_k}^T\end{equation}
By the way, Equation (3.15) can also be obtained via maximum likelihood criterion (Mohamed and Schwarz, Reference Lee, Lee, Hong, Kim and Seong1999). Comparing the two methods, subtraction in the IAE method inevitably results in negative definite Rk and then leads the filter to diverge. For this reason, the RAE method is more reliable and powerful in practical application. The measurement noise estimator in this paper is based on the RAE method.
3.2. AKF based on measurement noise estimator
It is noted that the measurement noise estimator based on IAE or RAE calculates Rk by the average of the innovations or residuals over all epochs. The average of the historical information may result in estimation latency. For example, when the measurement noise occurs in the hundredth epoch, the influence of the residual in the hundredth epoch to the system is merely 1% as the same as the epoch 1 to 99. The residuals which approach zero at the epoch 1 to 99 lead to sluggish and biased measurement noise estimation. From this point of view, it is necessary to reduce the weight of the historical epochs. Therefore, MW and EWMA are introduced.
The MW method employs a moving window to store the residuals and calculates the average of them for Rk. The EWMA method averages the residuals over all epochs with the exponential weight. The principles of the two methods are shown in Figure 2. The colour depth represents the average weight of the residual. The darker the colour, the greater the weight. It can be seen that Rk in the MW method is the average of the residuals in the moving window and in the EWMA method the closer to the current epoch, the greater the weight.
(a) Diagram of MW method. (b) Diagram of EWMA method

3.2.1 Measurement noise estimator based on MW
The MW method estimates the measurement noise matrix through computing the average of the residuals in a moving window, which effectively eliminates the influence of the historical information. The general equation of MW is:
 \begin{equation}{\hat{\boldsymbol{R}}_k} = \frac{1}{m}\sum\limits_{i = k - m + 1}^k {\Big\{{{\boldsymbol{\gamma }_i}\boldsymbol{\gamma }_i^T\textrm{ + }{\boldsymbol{H}_i}{\boldsymbol{P}_i}\boldsymbol{H}_i^T} \Big\}}\end{equation}
where m is the width of the moving window, and k is the current epoch.
To enhance the operation efficiency, Equation (3.16) can be expressed as:
 \begin{equation}{\hat{\boldsymbol{R}}_k} = {\hat{\boldsymbol{R}}_{k - 1}} + \frac{1}{m}\Big\{{\Big({{\boldsymbol{\gamma }_k}\boldsymbol{\gamma }_k^T\textrm{ + }{\boldsymbol{H}_k}{\boldsymbol{P}_k}\boldsymbol{H}_k^T} \Big)- \Big({{\boldsymbol{\gamma }_{k - m}}\boldsymbol{\gamma }_{k - m}^T\textrm{ + }{\boldsymbol{H}_{k - m}}{\boldsymbol{P}_{k - m}}\boldsymbol{H}_{k - m}^T} \Big)} \Big\}\end{equation}
The optimal width of the moving window is determined by the dynamic characteristic of the environment. In highly dynamic circumstances, the width of the moving window is required to be small to detect changes sensitively. Conversely, in low dynamic circumstances, the width of the moving window is required to be great to improve the stability of the system.
3.2.2. Measurement noise estimator based on EWMA
Rk of the EWMA method is estimated with the exponential weighted average of the residuals over all epochs. The closer to the current epoch, the greater the weight. It effectively reduces the undesirable influence of the historical sequence. The general equation of EWMA is (Sun et al., Reference Narasimhappa, Nayak, Terra and Sabat2016; Narasimhappa et al., Reference Liu, Zhao, Sun, Wu, Zhu and Zhang2018):
 \begin{equation}\begin{array}{l} {{\hat{\boldsymbol{R}}}_k} = (1 - {d_k}){{\hat{\boldsymbol{R}}}_{k - 1}} + {d_k}({\boldsymbol{\gamma }_k}\boldsymbol{\gamma }_k^T\textrm{ + }{\boldsymbol{H}_k}{\boldsymbol{P}_k}\boldsymbol{H}_k^T)\\ {d_k} = \dfrac{{1 - b}}{{1 - {b^{k + 1}}}} \end{array}\end{equation}
where k is the time step, dk is the forgetting factor, b is a constant, b∈(0⋅9,1].
It can be seen that the EWMA method estimates Rk by the residual of the current epoch and the calculated Rk- 1 of the previous epoch. Without the space to store the residuals of historical epochs and complex computing, EWMA is more applicable to implementation. The principle of EWMA is illustrated as follows:
To calculate the measurement noise covariance matrix Rk in the k-th epoch with the exponential weighted average of the residuals over the whole historical epochs, the recursive formula is given:
 \begin{equation}{\hat{\boldsymbol{R}}_k} = ({1 - d} ){\hat{\boldsymbol{R}}_{k - 1}} + d{\hat{\boldsymbol{R}}'_k}\end{equation}
where 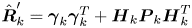 $\hat{\boldsymbol{R}}^{\prime}_{k} = {\boldsymbol{\gamma }_k}\boldsymbol{\gamma }_k^T + {\boldsymbol{H}_k}{\boldsymbol{P}_k}\boldsymbol{H}_k^T$.
With the recursive formula,  ${\hat{\boldsymbol{R}}_k}$ can be expanded as:
 \begin{equation}\begin{array}{l} {{\hat{\boldsymbol{R}}}_1} = ({1 - d} ){{\hat{\boldsymbol{R}}}_\textrm{0}} + d{{\hat{\boldsymbol{R}}}'_\textrm{1}} \\ {{\hat{\boldsymbol{R}}}_2} = ({1 - d} ){{\hat{\boldsymbol{R}}}_1} + d{{\hat{\boldsymbol{R}}}'_2} \textrm{ = }{({1 - d} )^2}{{\hat{\boldsymbol{R}}}_\textrm{0}} + ({1 - d} )d{{\hat{\boldsymbol{R}}}'_\textrm{1}} + d{{\hat{\boldsymbol{R}}}'_\textrm{2}} \\ {{\hat{\boldsymbol{R}}}_3} = ({1 - d} ){{\hat{\boldsymbol{R}}}_2} + d{{\hat{\boldsymbol{R}}}'_3} = {({1 - d} )^\textrm{3}}{{\hat{\boldsymbol{R}}}_\textrm{0}}\textrm{ + }{({1 - d} )^2}d{{\hat{\boldsymbol{R}}}'_1} + ({1 - d} )d{{\hat{\boldsymbol{R}}}'_2} + d{{\hat{\boldsymbol{R}}}'_3} \\ \ldots \\ {{\hat{\boldsymbol{R}}}_k} = ({1 - d} ){{\hat{\boldsymbol{R}}}_{k - 1}} + d{{\hat{\boldsymbol{R}}}'_k} = {({1 - d} )^k}{{\hat{\boldsymbol{R}}}_\textrm{0}} + {({1 - d} )^{k - \textrm{1}}}d{{\hat{\boldsymbol{R}}}'_\textrm{1}} + {({1 - d} )^{k - 2}}d{{\hat{\boldsymbol{R}}}'_2} + \cdots + d{{\hat{\boldsymbol{R}}}'_k} \end{array}\end{equation}
where  ${\hat{\boldsymbol{R}}_\textrm{0}}$ is set from experience and d is the forgetting factor, d∈(0,0⋅1]. It can be seen in the last equation of Equation (3.20) that Rk is the exponential weighted average over the historical epochs. Regretably, the multiplier d for the exponential item is missed in the first coefficient. For clarity, the weight of historical epoch in the 200th epoch (k = 200) is shown in Figure 3(a). It can be seen that the weight increases exponentially, but there is a conspicuous bias in the initial epoch. Consequently, the weight of the initial epoch is bigger than others. To address this problem, bias correction is introduced:
 \begin{equation}{d_k} = \frac{{1 - b}}{{1 - {b^{k + 1}}}},\;b \in [0.9,1)\end{equation}
(a) Weight in each epoch before bias correction. (b) dk in bias correction. (c) Weight in each epoch after bias correction. (d) Relation between weight in each epoch and b.

The value of dk is shown in Figure 3(b). As k increases, dk decreases from a large value to 1–b. When k = 1, 1/ dk is a small value. In consequence, the weight of the first epoch is reduced and the bias is corrected. The weight of each epoch with bias correction is shown in Figure 3(c). Compared with Figure 3(a), the bias is distinctly corrected.
Different b represents the different average performance. Figure 3(d) shows the relation of weight and b. It can be seen that the smaller b, the bigger the weight of the current epoch and the smaller the weight of the historical epochs. In highly dynamic circumstances, b is required to decrease to immediately detect changes. Conversely, in low dynamic circumstances, b is required to increase to improve the stability of the system. Therefore, an improved EWMA based on the adaptive b is proposed in the next section.
3.2.3. Measurement noise estimator based on IEWMA
In order to estimate the variable measurement noises in different dynamic environments and improve navigation accuracy, the measurement noise estimator based on IEWMA with adaptive forgetting factor is proposed in this paper.
Conceptually, the discrepancy between the residual covariance estimation and the theoretical residual covariance can be employed to evaluate the stability of the measurement noise estimator (Gao et al., Reference Gao, Gao, Hu, Zhong and Gu2015). The estimation convergence criterion can be represented as:
 \begin{equation}\Big|{{\boldsymbol{\gamma }^T}\boldsymbol{\gamma } - \kappa tr({{\hat{R}}_k} - {H_k}{P_{k,k - 1}}H_k^T)} \Big|\left\{ {\begin{array}{* {20}{l}} { \gt 0}&{\textrm{unstable}}\\ { = 0}&{\textrm{stable}} \end{array}} \right.\end{equation}
Where  $\kappa$ is constant and determined by the empirical knowledge.
According to the analysis in section 3.2, when the measurement noise is stable, the forgetting factor b is required to be large, whereas when the measurement noise is unstable, the forgetting factor b is required to be small. When b = 0⋅9, Rk is approximately the average over the 10 epochs before the current epoch. When b = 0⋅98, Rk is approximately the average over the 50 epochs, and it is the average over the whole epochs when b approaches 1. Empirically, it is appropriate to calculate Rk according to the average over 10 more epochs. Therefore,  $b \in [0.9,1)$ is supposed in the paper. Accordingly, in this paper the adaptive b is defined as:
 \begin{equation}b = 0.9 + 0.1{e^{ - |{{\boldsymbol{\gamma }^T}\boldsymbol{\gamma } - \kappa tr({{\hat{R}}_k} - {H_k}{P_{k,k - 1}}H_k^T)} |}}\end{equation}
where  $\kappa$ is constant and
 $\kappa \textrm{ = 5}$.
Figure 4 shows the relation between b and the exponential term. It can be seen that, with the increasing exponential term, the value of b increases from 0⋅9 to 1. In high dynamic circumstances, the exponential term is large and b approaches 0⋅9. Conversely, in low dynamic circumstances, the exponential term goes to zero and b approaches 1.
Relation between b and the exponential term

The superiority of the AKF based on IEWMA with the adaptive forgetting factor is listed as follows:
1. It is adaptable for various dynamic characteristics.
2. It can be applied to engineering practice without multiple experiences.
3. The estimation result is more stable in low dynamic circumstances and more sensitive in highly dynamic circumstances.
4. Simulation and vehicle tests
The performances of the SINS/DVL integrated system based on AFK with measurement noise estimator of MW, EWMA and IEWMA are evaluated on simulation and vehicle tests.
4.1. Simulation
A trajectory lasting for about 1,000 s with three straight lines and two curves is simulated. The simulated trajectory and vehicle dynamic characteristics are shown in Figures 5 and 6. The start point is set as latitude  $34^\circ \; \textrm{N}$ and longitude
 $108^\circ \; \textrm{E}$. The initial attitude is set as [0°, 0°, −90°]. The initial attitude error is set as [0⋅1°, 0⋅1°, 0⋅5°]. The drift bias and the random walk noise of the accelerometer are set as
 $50\,\mathrm{\mu g}$ and
 $50\,\mathrm{\mu g}/\sqrt {\textrm{Hz}} $, and those of the gyroscope are set as
 $0.01^\circ /\sqrt h $ and
 $0.01^\circ /\sqrt h $. The DVL scale factor is set as 0⋅005. The update rates of the IMU and DVL are set as 200 Hz and 1 Hz, respectively.
Trajectory of the vehicle in simulation

Dynamic characteristics of vehicle in simulation

In order to compare the performances of these methods, it is simulated that a graded noise with the sine function of 5 m/s occurs from 750 s to 900 s whereas the noise at other times is zero-mean white noise with standard deviation of 0⋅1 m/s. Fairly, the optimal window length was found to be 50, and the forgetting factor b = 0⋅97 after quite a few experiments to compare with the proposed method. Meanwhile, the conventional KF was also carried out to emphasise the performance of the proposed method. The comparisons of attitude, velocity and position errors of the four algorithms are shown in Figures 7–9, where the blue line, red line, green line and orange line represent KF, MW, EWMA and IEWMA, respectively. When noise occurs, the conventional KF immediately diverges. Conversely, with the measurement noise estimator, other methods are relatively stable. Looking at the enlarged drawing, we can find that the errors of IEWMA method are more stable and smaller than the others.
Attitude errors of four methods in simulation

Velocity errors of four methods in simulation

Position errors of four methods in simulation

In order to compare intuitively the performances of the four methods, the horizontal position errors of KF and AKF with the measurement noise estimators of MW, EWMA and IEWMA are shown in Figure 10. It can be seen that the horizontal position error of IEWMA is more stable and smaller than the others.
Horizontal position errors of four methods in simulation

Quantitative analysis was carried out on the navigation errors via the mean representing the size of the errors and the root mean square (RMS) representing the stability of the errors. The mean and RMS of the attitude, velocity and position errors are shown in Tables 1 and 2, respectively. The mean and RMS of horizontal position errors in the four methods are shown in Table 3.
Mean of attitude, velocity and position errors in four methods

RMS of attitude, velocity and position errors in four methods

Mean and RMS of horizontal position errors in four methods

From Table 1, we can see that the mean of velocity and position errors in IEWMA is smaller than the others. The differences of attitude error in MW, EWMA and IEWMA are negligible. Meanwhile, the RMS of all errors in the IEWMA method is smaller than the others in Table 2. It is also obvious that the mean and RMS of horizontal position error in IEWMA are smaller than the others in Table 3. Therefore, it is concluded that IEWMA outperforms MW and EWMA in both navigation accuracy and stability.
As mentioned, performance of the integrated system depends on the accuracy of the estimated Rk. The estimated Rk is shown in Figure 11. As anticipated, Rk of IEWMA is the nearest to the true value. On the one hand, Rk of IEWMA is more stable than the others in 0 s to 600 s. This is because, in cases where the measurement noise is stable, adaptive forgetting factor b becomes as small as possible. Accordingly, the weight of the current epoch decreases and the weight of historical sequence increases. On the other hand, Rk of IEWMA is more susceptible than others in 750 s to 900 s. Similarly, when noise occurs, adaptive forgetting factor b becomes as large as possible. Accordingly, the weight of the current epoch increases and the weight of the historical sequence decreases. The undesirable influence of historical sequence in IEWMA is eliminated. However, Rk of MW and EWMA is still influenced by the historical sequence and it is hysteretic to the volatile noise.
Diagram of estimated Rk in simulation

4.2. Vehicle test
The proposed method was evaluated in land vehicle field testing to predict the feasibility of its operation in underwater environments. In the SINS/DVL navigation system used in the vehicle test, the inertial information is provided by the IMU and the velocity information of DVL is replaced by the PHINS which is developed by French firm IXBLU. PHINS transforms its own velocity from navigation frame to body frame using the true attitude information to provide the DVL information. A computer was utilised to perform a series of navigation operations. The installation structure is shown in Figure 12. The specifications of the IMU and PHINS are listed in Table 4.
Installation structure for land trial

Specifications of IMU and PHINS

The land trial was conducted near 31° 88′N, 118° 82′E, on the campus of Southeast University. The vehicle trajectory, lasting for 1,200 s, is shown in Figure 13 and vehicle dynamic characters are shown in Figure 14.
Trajectory of the vehicle in land trial

Dynamic characteristics of vehicle in land trial

In the vehicle test, the graded noise with the sine function of 5 m/s is contrived from 800 s to 950 s to compare the performances of these methods. Fairly, the optimal width of the moving window for MW is set as 50 and the optimal forgetting factor b for EWMA is set as 0⋅98 after multiple experiences. The attitude, velocity and position errors of the four methods are shown in Figures 15–17. Meanwhile, horizontal position errors are shown in Figure 18. Similarly, the errors of the IEWMA method are the most stable and lowest in the four methods, which effectively verifies the feasibility of the proposed method.
Attitude errors of four methods in land trial

Velocity errors of four methods in land trial

Position errors of four methods in land trial

Horizontal position errors of four methods in land trial

Simultaneously, quantitative analysis is performed. The mean and RMS of attitude, velocity, individual position and horizontal position errors are shown in Tables 5–7. From Tables 5 and 6, we can see that the mean and RMS of errors for IEWMA is smaller than for KF, MW and EWMA. In Table 7, it is obvious that the mean and RMS of horizontal position error for IEWMA are smaller than the others. Therefore, the IEWMA method outperforms the other methods in both navigation accuracy and stability.
Mean of attitude, velocity and position errors in four methods

RMS of attitude, velocity and position errors in four methods

Mean and RMS of horizontal position errors in four methods

As mentioned, the performance of the integrated system depends on the accuracy of Rk. The estimated Rk is shown in Figure 19. It can be seen that Rk of IEWMA is more stable than MW and EWMA at the initial moments (0 s to 600 s). This is because the width of the moving window in MW and the forgetting factor b of EWMA cannot meet the requirements of the environment. Conversely, the adaptive forgetting factor b of IEWMA can decrease to adapt to the stable environment. Additionally, the estimated Rk of IEWMA is the closest to true value, while MW and EWMA are sluggish when noise occurs (800 s to 950 s). When the measurement noise occurs, the forgetting factor of IEWMA becomes smaller, and the weight of the residual in current time increases, which can be sensitive to changes. However, because of the fixed width of the moving window and forgetting factor b, MW and EWMA are still affected by the historical sequence and are too sluggish to estimate the noise accurately.
Diagram of the estimated Rk in land trial

5. Conclusions
To eliminate navigation errors introduced by the DVL error in complex underwater environments, an AKF with measurement noise estimator is proposed in this paper. The measurement noise estimator provides accurate noise statistical characteristics for the filter to improve navigation performance. In order to reduce the influence of the historical sequence on the estimated Rk, an adaptive forgetting factor is introduced to the measurement noise estimator for applying to various noise dynamic characteristics. The proposed IEWMA method can be directly utilised in an unknown environment and can adapt to various noise dynamic characteristics. Results of simulation and experience tests show that the AKF based on the measurement noise estimator of the proposed IEWMA method has better performance than MW and EWMA methods in terms of the measurement noise estimation and the navigation accuracy. The navigation results are more stable in low dynamic circumstances and more sensitive in highly dynamic circumstances.
Acknowledgements
The authors would like to thank all members of the Key Laboratory of Micro-Inertial Instrument and Advanced Navigation Technology for the technology assistance with the integrated navigation system. This work was supported by the National Nature Science Foundation of China under grants 51775110, 61921004 and in part by the Natural Science Foundation of Jiangsu Province, China under Grant BK20190344.



