1.0 INTRODUCTION
A hypersonic vehicle is an aircraft with a M > 5. Because of the large airspace and high manoeuvre characteristics of a hypersonic vehicle, coupled with the complex and ever-changing environment, it has led to great difficulties in the modelling and controller design(Reference Voland, Huebner and Mcclinton1,Reference Xu and Shi2) . The commonly used non-linear control methods for hypersonic vehicle controller design include the following: feedback linearisation method, gain pre-set method, adaptive method, sliding mode variable structure method and so on. Moreover, due to its fast speed and complex environment, various faults are prone to occur(Reference Friedmann and Mcnamara3) that may cause system performance deterioration that can further produce accidents. Therefore, to guarantee system stability under faults, fault-tolerant control is of great significance(Reference Shen, Jiang and Cocquempot4,Reference Chen, Wang and Tao5) .
There have been some studies on fault-tolerant control of hypersonic vehicles under actuator fault with parametric uncertainties and disturbance(Reference He, Qi and Jiang6–Reference Wang, Zong and He8). An adaptive output feedback fault-tolerant controller is developed in the presence of parameter uncertainties, actuator faults and external disturbances in Ref. Reference He, Qi and Jiang6. Niu(Reference Niu, Chen and Tao7) presented a non-linear fuzzy fault-tolerant control and a fault observer for the longitudinal dynamics model of a hypersonic vehicle with parameter uncertainties and actuator gain loss faults. Wang(Reference Wang, Zong and He8) proposed an adaptive sliding mode fault-tolerant control method to solve loss-of-benefit problems for actuators with known structures using the dynamic change of the integral sliding surface to detect the occurrence of actuator faults in real time.
However, it is impossible for the actuator to increase the control input without limitation to compensate for the fault in the actual control system. If the controller is designed without saturation, the output of the controller will be inconsistent with the design in actual application, resulting in a performance degradation of the closed-loop system and even instability of the system(Reference Askari, Shahrokhi and Talkhoncheh9). An adaptive sliding mode observer-based fault-tolerant control method taking into consideration actuator saturation is proposed for a hypersonic vehicle under a class of time-varying actuator faults(Reference Mu, Li and Yu10). Groves K(Reference Groves, Serrani and Yurkovich11) proposed a method based on anti-saturation control. Reference Reference Gibson, Crespo and Annaswamy12 considered the adaptive controller design problem with the uncertainties of aerodynamic parameters, actuator saturation and time lag. But the algorithms in Refs Reference Mu, Li and Yu10–Reference Gibson, Crespo and Annaswamy12 are based on the linearisation model of the hypersonic vehicle longitudinal model. Sun(Reference Sun, Li and Sun13) then designed an adaptive integral sliding mode fault-tolerant controller based on the dynamic inverse method for the non-linear system with multiple actuator faults and external disturbances. The controller can achieve asymptotically stable tracking of the flight output reference commands, but the convergence speed is not very fast. And most of the current results mentioned above are for the gain loss fault of actuator, in the actual system, the stuck fault should be considered as well. The research on the actuator stuck fault of hypersonic vehicle is not rich. So, it is necessary to propose a fault-tolerant control method that can simultaneously address actuator gain loss fault and stuck fault.
In response to the above problems, this paper proposes a fault-tolerant control method of hypersonic vehicles based on fast fault observer under gain loss fault or stuck fault that considers parametric uncertainties, control input saturation and disturbance. The main problems to be solved include:
1. In the design of the controller in this paper, situations such as control input saturation, disturbance, parametric uncertainties and actuator faults are considered comprehensively.
2. An improved fast fault observer (FFO) is designed that can quickly detect the integrated fault (control input saturation, disturbances and actuator faults) and compensate so that the fault can be processed at the first time.
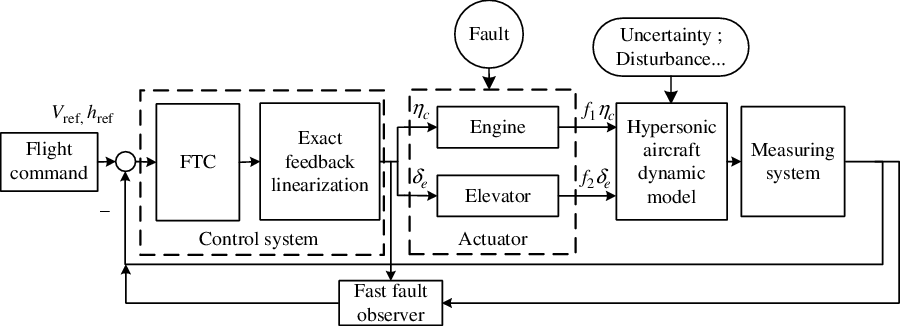
3. The controller can simultaneously address actuator gain loss fault and stuck fault. Figure 1 shows the basic block diagram of the flight control system in this paper.
Figure 1.Basic control diagram of flight control system.


2.0 PROBLEM FORMULATION
2.1 Longitudinal dynamics of hypersonic aircraft
The 6-degree-of-freedom non-linear dynamic model of a hypersonic vehicle can be derived into the following longitudinal dynamics model developed by the NASA Langley Research Center(Reference Bolender14):
 \begin{equation}\left\{ {\begin{array}{l}{\dot V = (T\cos \alpha - D)/m - g\sin \gamma }\\[5pt]{\dot \gamma = (L + T\sin \alpha )/mV - (g\cos \gamma )/V}\\[5pt]{\dot q = {M_y}/{I_y}}\\[5pt]{\dot \alpha = q - \dot \gamma }\\[5pt]{\dot h = V\sin \gamma }\end{array}} \right.\end{equation}
where  $V,\gamma ,\alpha ,q,h$
are velocity, flight-path angle, angle-of-attack, pitch rate and altitude;
 ${I_y}$
is the moment of inertia;
 ${M_y} = 0.5\rho {V^2}S\bar c{C_M}$
is the pitching moment;
 $\rho$
, S,
 $\bar c$
mean the density of the air, reference area, and average aerodynamic chord length, respectively. Both the gravitational acceleration and atmospheric density are altitude-dependent models as:
 $g = {g_0}{({r_0}/{r_0} + h)^2}$
,
 $\rho = {\rho _0}{e^{ - h/7315.2}}$
; the polynomial fitting of the aerodynamic coefficients near equilibrium point is performed under cruise conditions (V = 4,590.3m/s, h = 33,528m
 $\gamma = {0^ \circ },\,\alpha = {2.745^ \circ }, \,q = {0^ \circ }/s)$
, for the lift L, drag D and thrust T, we have
 $L = 0.5\rho {V^2}S{C_L}$
,
 $D = 0.5\rho {V^2}S{C_D}$
,
 $T = 0.5\rho {V^2}S{C_T}$
. Forces and moment coefficients are described as(Reference Sigthorsson and Serrani15):
 \begin{equation} \begin{cases} {C_L} = 0.6203\alpha ; \\[5pt] {C_D} = 0.6450{\alpha ^2} + 0.0043378\alpha + 0.003772 \\[5pt] {C_T} = \begin{cases} {0.02576\eta } & if\ \eta < 1 \\[5pt] 0.0224 + 0.00336\eta & if\ \eta \ge 1 \end{cases} \\[5pt] C_M^\alpha = - 0.035{\alpha ^2} + 0.036617\alpha + 5.3261 \times {10^{ - 6}} \\[5pt] C_M^q = \frac{{\bar c}q}{2V}( - 6.796{\alpha ^2} + 0.3015\alpha - 0.2289) \\[5pt] C_M^{{\delta _e}} = {c_e}\left( {{\delta _e} - \alpha } \right); \\[5pt] {C_M} = C_M^\alpha + C_M^q + C_M^{{\delta _e}}; \\[5pt] {c_e} = 0.0292 \end{cases}\end{equation}
where  $\ddot \eta = - 2\zeta {\omega _n}\dot \eta - \omega _n^2\eta + \omega _n^2{\eta _c}$
is the engine thrust model,
 ${\eta _c}$
means the engine throttle setting command, which is determined by the combustion efficiency and thrust coefficient of the engine;
 ${\omega _n}$
and
 $\zeta $
are the natural frequency and damping coefficient, respectively.
2.2 Input-output feedback linearisation
The model described in Equation (1) is highly non-linear and coupled, the third derivative of V and the fourth derivative of h are obtained as follows(Reference Xu, Mirmirani and Ioannou16):
 \begin{equation}\begin{cases} \ddot V = \Theta _1^T{{\dot x}_1}/m \\
\dddot{V} = (\Theta _1^T{{\ddot x}_1} + {{\dot x}_1}^T{\Theta _2}{{\dot x}_1})/m \end{cases}\end{equation}
 \begin{equation}\begin{cases} \ddot h = \dot V\sin \gamma + V\dot \gamma \cos \gamma \\
\dddot{h} = \ddot V\sin \gamma + 2\dot V\dot \gamma \cos \gamma - V{{\dot \gamma }^2}\sin \gamma + V\ddot \gamma \cos \gamma \\
{h^{(4)}} = \dddot{V}\sin \gamma + V\dddot{\gamma}\cos \gamma + 3\ddot V\dot \gamma \cos \gamma \\
\qquad - 3\dot V{{\dot \gamma }^2}\sin \gamma + 3\dot V\ddot \gamma \cos \gamma - 3V\dot \gamma \ddot \gamma \sin \gamma - V{{\dot \gamma }^3}\sin \gamma \end{cases}\end{equation}
where the second and third derivative expression of flight-path angle are
 \begin{equation}\begin{cases} \ddot \gamma = \Xi _1{{\dot x}_1} \\
\dddot{\gamma} = \Xi _1^T{{\ddot x}_1} + {{\dot x}_1}^T{\Xi _2}{{\dot x}_1} \end{cases}\end{equation}
where  ${x_1} = {[V,\gamma ,\alpha ,\eta ,h]^T}$
,
 ${\Theta _1},{\Theta _2}$
,
 ${\Xi _1},{\Xi _2}$
are presented in Ref. Reference Wang, Zong and He8 and the Appendix, and the non-linear system can be equivalent to the following model:
 \begin{equation}\left[ \begin{array}{l} \dddot{V} \\
{h^{(4)}} \end{array} \right] = \left[ \begin{array}{c} {f_V} \\ {f_h} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {b_{11}} & {{b_{12}}} \\ {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c} {{\eta _c}} \\ {{\delta _e}} \end{array} \right]\end{equation}
where
 \begin{equation}{f_V} = \frac{{{\varTheta _1}{{\ddot x}_0} + {{\dot x}_1}^T{\varTheta _2}{{\dot x}_1}}}{m}\end{equation}
 \begin{equation}\begin{array}{l}{f_h} = 3\ddot V\dot \gamma \cos \gamma - 3\dot V{{\dot \gamma }^2}\sin \gamma + 3\dot V\ddot \gamma \cos \gamma - 3V\dot \gamma \ddot \gamma \sin \gamma {\kern 1pt} - V{{\dot \gamma }^3}\sin \gamma \\[5pt]
\qquad + ({\varTheta _1}{{\ddot x}_0} + {{\dot x}_1}^T{\varTheta _2}{{\dot x}_1})\sin \gamma /m + V\cos \gamma ({\varXi _1}{{\ddot x}_0} + {{\dot x}_1}^T{\varXi _2}{{\dot x}_1})\end{array}\end{equation}
 \begin{equation}{b_{11}} = (\rho {V^2}S{c_\beta }\omega _n^2/2m)\cos \alpha \end{equation}
 \begin{equation}{b_{12}} = - ({c_e}\rho {V^2}S\bar c/2m{I_y})(T\sin \alpha + {D_\alpha })\end{equation}
 \begin{equation}{b_{21}} = (\rho {V^2}S{c_\beta }\omega _n^2/2m)\sin (\alpha + \gamma )\end{equation}
 \begin{equation}{b_{22}} = ({c_e}\rho {V^2}S\bar c/2m{I_y})[T\cos (\alpha + \gamma ) + {L_\alpha }\cos \gamma - {D_\alpha }\sin \gamma ]\end{equation}
2.3 Hypersonic aircraft fault model
Parametric uncertainties: By referring to the previous research, it can be assumed that a hypersonic vehicle has the following parameter uncertainties in the actual mission: (1) Inertia parameters – mass  $m = {m_0}(1 + {\Delta _m})$
, moment of inertia
 ${I_y} = {I_y}_0(1 + {\Delta _{{I_y}}})$
; (2) Geometric parameters – reference aerodynamic area
 $S = {S_0}(1 + {\Delta _S})$
, average aerodynamic chord length
 $\bar c = {\bar c_0}(1 + {\Delta _{\bar c}})$
; (3) Environmental parameters – density of air
 $\rho = {\rho _0}(1 + {\Delta _\rho })$
, gravity acceleration
 $g = {g_0}(1 + {\Delta _g})$
; (4) Forces and moment parameters – lift coefficient
 ${C_L} = {C_L}_0(1 + {\Delta _{{C_L}}})$
, drag coefficient
 ${C_D} = {C_D}_0(1 + {\Delta _{{C_D}}})$
, pitching moment coefficient
 ${c_e} = {c_e}_0(1 + {\Delta _{{c_e}}})$
, where
 ${\Delta _{( \bullet )}}$
means an unknown constant indicating the magnitude of the perturbation of each parameter. The control objective is to design an appropriate controller to ensure that the aircraft can have a good tracking performance for altitude commands and speed commands without any parameter uncertainties.
Disturbance: Considering external disturbances  ${d_1}(t)$
,
 ${d_2}(t)$
as unknown time-varying functions, can see:
 \begin{equation}\left[ \begin{array}{c} \dddot{V} \\[3pt] {h^{(4)}} \end{array} \right] = \left[ \begin{array}{c} {f_V} \\[3pt] {f_h} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[3pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c} {{\eta _c}} \\[3pt] {{\delta _e}} \end{array}\right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[3pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c} {{d_1}(t)} \\[3pt] {{d_2}(t)} \end{array} \right]\end{equation}
Input saturation: Considering the control input saturation  $u = \textrm{sat}(u)$
, where
 $sat(u) = {[sat({u_1}),sat({u_2})]^T}$
means the actuator has the following non-linear saturation characteristics:
 \begin{equation}sat({u_i}) = \begin{cases} {u_{li}} & {u_i} > {u_{li}} \\ {u_i}& - {u_{li}} \le {u_i} \le {u_{li}} \\ - {u_{li}} & - {u_i} < {u_{li}} \end{cases}\end{equation}
where  ${u_{li}}$
is the upper limit of the control input
 ${u_i}(i = 1,2)$
. In this paper, input saturation effects are considered as the elevator and the throttle of the longitudinal model of the aircraft.
Actuator fault: Considering the control gain loss fault and stuck fault of hypersonic vehicle, if the control gain is not completely lost, the actuators can still work, but the efficiency of the control is reduced. From the above accurate feedback linearisation model (6), it is known that in this paper the actuator considers  ${\eta _c}$
and
 ${\delta _e}$
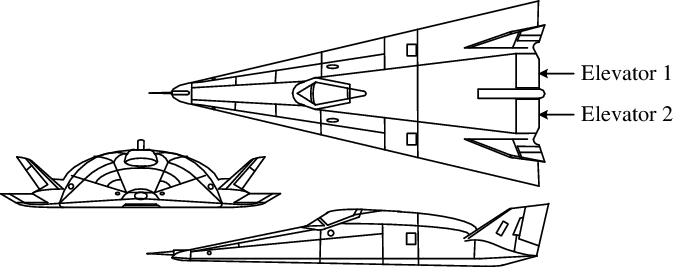
of the hypersonic vehicle. Considering that the aircraft has two elevators
 ${\delta _e} = {a_1}{\delta _{e1}} + {a_2}{\delta _{e2}}$
, as shown in Fig. 2, where
 ${a_1},{a_2}$
are the proportional gains of the two elevators. When the ith elevator is stuck or has gain loss fault, the output of the elevator is
 ${u_{ei}}$
.
 \begin{equation}{u_{ei}} = {f_{ei}}{v_{ei}} + (1 - {\sigma _i}){\bar \delta _{ei}},i = 1,2\end{equation}
where  ${f_{ei}}$
is the fault factor of the ith elevator,
 ${v_{ei}}$
is the input of the ith elevator and
 ${\bar \delta _{ei}}$
means the position where the ith elevator is stuck. When
 ${\sigma _i}=1,0 < {f_i} < 1$
, the actuator has gain loss fault. When
 ${\sigma _i}=0,{f_i}=0$
, the actuator has stuck fault.
Three-view drawing of hypersonic vehicle.

Because the surfaces in the longitudinal dynamics model (6) are only two elevators, if they are stuck at the same time, the system will not work. Therefore, it is assumed in this paper that there is no situation that two elevators are stuck at the same time. When one of the elevators is stuck or has gain loss fault, or both have gain loss fault at the same time, it is a loss of efficiency for the elevator as a whole, which can be expressed as:
 \begin{equation}{u_e} = {a_1}{u_{e1}} + {a_2}{u_{e2}} = {f_{e1}}{v_{e1}} + (1 - {\sigma _1}){\bar \delta _{e1}} + {f_{e2}}{v_{e2}} + (1 - {\sigma _2}){\bar \delta _{e2}} = {f_2}{v_e}\end{equation}
where  ${v_e}$
means the sum of the elevator inputs,
 ${u_e}$
means the sum of the elevator outputs,
 ${f_{e1}}$
,
 ${f_{e2}}$
mean the fault loss factors of the two elevators and
 ${f_2}$
means the overall fault coefficient of the elevator,
 ${f_2}$
can be obtained by proportional. Therefore, the system with the fault is re-described as follows:
 \begin{equation}\left[ \begin{array}{c} \dddot{V} \\ h^{(4)} \end{array} \right] = \left[ \begin{array}{c} {f_V} \\ {f_h} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\ {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c@{\quad}c} {{f_1}} & 0 \\ 0 & {{f_2}} \end{array} \right]\left[ \begin{array}{c} {{\eta _c}} \\ {{\delta _e}} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\ {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c} {{d_1}(t)} \\ {{d_2}(t)} \end{array} \right]\end{equation}
where  $diag\{ \,{f_1},{f_2}\} $
represents the unknown control gain loss fault caused by the control input-engine throttle setting value
 ${\eta _c}$
of the hypersonic vehicle and the stuck or gain loss fault caused by the elevator deflection angle
 ${\delta _e}$
. And it is satisfied by
 $0 \le {f_i} \le 1$
.
3.0 IMPROVED FAST FAULT OBSERVER DESIGN
Israel’s Levant(Reference Levant and Livne17) proposed an arbitrary-order sliding mode observer to perform real-time online estimation of the differential terms in the controller. It is assumed that the input signal is composed of a bounded signal and a disturbance, where the bounded signal  $f(t) \in {L^{(n)}} \subseteq {C^{(n)}}$
is a signal without measurement noise; that is,
 $f(t) = {f_0}(t)$
. A real-time approximation can be performed on any derivative of any order-based observer of
 ${f_0}(t)$
and can construct the following dynamic system:
 \begin{equation}\left\{ \begin{array}{l}{{\dot z}_0} = {v_0}\\[5pt]{v_0} = - {\lambda _0}{L^{(1/(n + 1)}}{\left| {{z_0} - f(t)} \right|^{(n/(n + 1))}}{\rm{sign}}({z_0} - f(t)) + {z_1}\\[5pt]{{\dot z}_1} = {v_1}\\[5pt]{v_1} = - {\lambda _1}{L^{1/n}}{\left| {{z_1} - {v_0}} \right|^{(n - 1/n)}}{\rm{sign}}({z_1} - {v_0}) + {z_2}\\[5pt] \vdots \\[5pt]{{\dot z}_{n - 1}} = {v_{n - 1}}\\[5pt]{v_{n - 1}} = - {\lambda _{n - 1}}{L^{1/2}}{\left| {{z_{n - 1}} - {v_{n - 2}}} \right|^{1/2}}{\rm{sign}}({z_{n - 1}} - {v_{n - 2}}) + {z_n}\\[5pt]{{\dot z}_n} = - {\lambda _n}L{\rm{sign}}({z_n} - {v_{n - 1}})\end{array} \right.\end{equation}
where  ${\lambda _i} > 0(i = 0,1,2,...,n)$
is a constant greater than zero and L is a constant given in advance, which is satisfied
 ${f^{(n + 1)}}(t) \le L$
. In general, L can be obtained by multiple simulations of the computer. The above system constitutes a singular time-smoothing sliding mode differentiator, and there is a time constant
 ${t_\infty }$
when
 $t > {t_\infty }$
,
 ${z_0}(t) = {f_0}(t)$
,
 ${z_i}(t) = {v_{i - 1}}(t) = f_0^{(i)}(t) = 0,$
 $i = 1,2,...,n$
.
The former n-1 layer in the traditional high-order observer adopts the form of the terminal sliding mode, offering two advantages: one can converge in a finite time, and the other is that the trajectory remains smooth. However, there is a discontinuous sliding surface when designing the nth sliding surface, which causes the nth layer of the observer to be buffeted and each layer to be coupled. So, the output of the other layers will be affected at the same time. In response to the above problem, the terminal function is used instead of the original symbol function.
 \begin{equation}\left\{ \begin{array}{l}{{\dot z}_0} = {v_0}\\[5pt]{v_0} = - {\lambda _0}{L^{(1/(n + 1)}}{\left| {{z_0} - f(t)} \right|^{(n/(n + 1))}}{\rm{sign}}({z_0} - f(t)) + {z_1}\\[5pt]{{\dot z}_1} = {v_1}\\[5pt]{v_1} = - {\lambda _1}{L^{1/n}}{\left| {{z_1} - {v_0}} \right|^{(n - 1/n)}}{\rm{sign}}({z_1} - {v_0}) + {z_2}\\[5pt] \vdots \\[5pt]{{\dot z}_{n - 1}} = {v_{n - 1}}\\[5pt]{v_{n - 1}} = - {\lambda _{n - 1}}{L^{1/2}}{\left| {{z_{n - 1}} - {v_{n - 2}}} \right|^{1/2}}{\rm{sign}}({z_{n - 1}} - {v_{n - 2}}) + {z_n}\\[5pt]{{\dot z}_n} = - {\lambda _n}L{\left| {{z_n} - {v_{n - 1}}} \right|^{\rm{q/p}}}{\rm{sign}}({z_n} - {v_{n - 1}})\end{array} \right.\end{equation}
where p and q are the parameters of terminal attractor,  $p > 0,q > 0,p > q$
, and the rest of the parameters are similar to the original observer,
 $ - {\lambda _n}L{\left| {{z_n} - {v_{n - 1}}} \right|^{\rm{q/p}}}{\rm{sign}}({z_n} - {v_{n - 1}})$
can make
 ${z_n} - {v_{n - 1}}$
converge to 0 in a finite time and
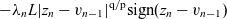 $ - {\lambda _n}L{\left| {{z_n} - {v_{n - 1}}} \right|^{\rm{q/p}}}{\rm{sign}}({z_n} - {v_{n - 1}})$
close to 0. And inspired by the fast terminal sliding mode, Equation (19) can be improved as follows, and the FFO is obtained:
 \begin{align} \begin{cases}{{\dot z}_0} = {v_0}\\[5pt]{v_0} = - {\lambda _{0,1}}({z_0} - f(t)) - {\lambda _{0,2}}{L^{(1/(n + 1)}}{\left| {{z_0} - f(t)} \right|^{(n/(n + 1))}}{\rm{sign}}({z_0} - f(t)) + {z_1}\\[5pt]{{\dot z}_1} = {v_1}\\[5pt]{v_1} = - {\lambda _{1,1}}({z_1} - {v_0}) - {\lambda _{1,2}}{L^{1/n}}{\left| {{z_1} - {v_0}} \right|^{(n - 1/n)}}{\rm{sign}}({z_1} - {v_0}) + {z_2}\\[5pt] \vdots \\[5pt]{{\dot z}_{n - 1}} = {v_{n - 1}}\\[5pt]{v_{n - 1}} = - {\lambda _{n - 1,1}}({z_{n - 1}} - {v_{n - 2}}) - {\lambda _{n - 1,2}}{L^{1/2}}{\left| {{z_{n - 1}} - {v_{n - 2}}} \right|^{1/2}}{\rm{sign}}({z_{n - 1}} - {v_{n - 2}}) + {z_n}\\[5pt]{{\dot z}_n} = - {\lambda _{n,1}}({z_n} - {v_{n - 1}}) - {\lambda _{n,2}}L{\left| {{z_n} - {v_{n - 1}}} \right|^{\rm{q/p}}}{\rm{sign}}({z_n} - {v_{n - 1}})\end{cases} \\[-20pt]\nonumber\end{align}
where  ${\lambda _{0,1}},{\lambda _{0,2}},{\lambda _{1,1}},{\lambda _{1,2}}...$
are the parameters of the observer that needs to be designed. The FFO speeds up the convergence. It can also improve the convergence time increase caused by the increased order and has stronger adaptability to the interference suppression ability than the traditional observer.
In recent years, high-order sliding mode observers have been applied in many control systems, and have also been applied in engineering, with the advantages of accuracy and real-time. In this paper, the original observer is improved for better performance.
4.0 FTC CONTROLLER DESIGN
The reference velocity and altitude are denoted as  ${V_{{\rm ref}}}$
and
 ${h_{\rm ref}}$
. Defining command tracking errors
 ${e_V} = V - {V_{\rm ref}}$
and
 ${e_h} = h - {h_{\rm ref}}$
, the integral sliding surface is defined as follows:
 \begin{equation}\left\{ \begin{array}{l}\displaystyle{S_V} = \dfrac{{{{\rm{d}}^2}}}{{{\rm{d}}{t^2}}}{e_V} + 3{\lambda _V}\dfrac{{\rm{d}}}{{{\rm{d}}t}}{e_V} + 3{\lambda _V}^2{e_V} + {\lambda _V}^3\int_0^t {{e_V}(\tau ){\rm{d}}\tau } + {C_V}\\[12pt] \displaystyle{S_h} = \dfrac{{{{\rm{d}}^3}}}{{{\rm{d}}{t^3}}}{e_h} + 4{\lambda _h}\dfrac{{{{\rm{d}}^2}}}{{{\rm{d}}{t^2}}}{e_h} + 6{\lambda _h}^2\dfrac{{\rm{d}}}{{{\rm{d}}t}}{e_h} + 4{\lambda _h}^3{e_h} + {\lambda _h}^4\int_0^t {{e_h}(\tau ){\rm{d}}\tau } + {C_h}\end{array} \right.\end{equation}
where  ${\lambda _V} > 0$
and
 ${\lambda _h} > 0$
determine the performance of the sliding mode motion.
 ${C_V}$
and
 ${C_h}$
are constants, which should be chosen as appropriate values to make the initial value of the sliding surface
 ${S_V}(0) = 0$
,
 ${S_h}(0)=0$
so that the system is in a sliding mode motion from the beginning to avoid the control inputs changing too much in the initial stage. The integral terms are used to eliminate steady-state errors. Deriving the above sliding mode and substituting the linearised model into variables:
 \begin{align} & \left[ \begin{array}{c} {{\dot S}_V} \\[3pt] {{\dot S}_h} \end{array} \right] = \left[ \begin{array}{l} {\dddot{e}_V} + 3{\lambda _V}{{\ddot e}_V} + 3\lambda _V^2{{\dot e}_V} + \lambda _V^3{e_V} \\[3pt] e_h^{(4)} + 4{\lambda _h}{\dddot{e}_h} + 6\lambda _h^2{{\ddot e}_h} + 4\lambda _h^3{{\dot e}_h} + \lambda _h^4{e_h} \end{array} \right] \nonumber\\[8pt]
& = \left[ \begin{array}{c} {f_V} \\[3pt] {f_h} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[3pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c@{\quad}c} {{f_1}} & 0 \\[3pt] 0 & {{f_2}} \end{array} \right]\left[ \begin{array}{c} {sat({\eta _c})} \\[3pt] {sat({\delta _e})} \end{array} \right] + \left[ \begin{array}{l} 3{\lambda _V}{{\ddot e}_V} + 3\lambda _V^2{{\dot e}_V} + \lambda _V^3{e_V} \\[3pt] 4{\lambda _h}{\dddot{e}_h} + 6\lambda _h^2{{\ddot e}_h} + 4\lambda _h^3{{\dot e}_h} + \lambda _h^4{e_h} \end{array} \right] \nonumber\\[8pt]
& \quad -\left[ \begin{array}{c} {\dddot{V}_{\rm ref}} \\[5pt] {h_{\rm ref}}^{(4)} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[5pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c} {{d_1}(t)} \\[5pt] {{d_2}(t)} \end{array} \right] \end{align}
Set the limitation of input saturation to  $\Psi (u) = \left[ \begin{array}{*{20}{c}}{{\Psi _1}({u_1})}\\{{\Psi _2}({u_2})}\end{array} \right]$
,
 ${\Psi _i}({u_i}),i = 1,2$
can be defined as:
 \begin{equation}{\Psi _i}({u_i}) = \left\{ \begin{array}{l@{\qquad}l} {u_{li}} - {u_i} & {u_i} > {u_{li}} \\[3pt]
0 & - {u_{li}} \le {u_i} \le {u_{li}} \\[3pt]
- {u_{li}} - {u_i} & {u_i} \le - {u_{li}} \end{array}\right., i = 1,2 \end{equation}
then
 \begin{equation}sat(u) = \Psi (u) + u\end{equation}
 \begin{align} \left[ \begin{array}{c} {{\dot S}_V} \\[3pt] {{\dot S}_h} \end{array} \right] & = \left[ \begin{array}{c} {f_V} \\[3pt] {f_h} \end{array} \right]-\left[ \begin{array}{c} {\dddot{V}_{\rm ref}} \\[3pt] {h_{\rm ref}}^{(4)} \end{array} \right] + \left[ \begin{array}{l} 3{\lambda _V}{{\ddot e}_V} + 3\lambda _V^2{{\dot e}_V} + \lambda _V^3{e_V} \\[3pt] 4{\lambda _h}{\dddot{e}_h} + 6\lambda _h^2{{\ddot e}_h} + 4\lambda _h^3{{\dot e}_h} + \lambda _h^4{e_h} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[3pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c} {{\eta _c}} \\[3pt] {{\delta _e}} \end{array} \right] \nonumber\\[6pt]
&\quad - \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[3pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c@{\quad}c} {1 - {f_1}} & 0 \\[3pt] 0 & {1 - {f_2}} \end{array} \right]\left[ \begin{array}{c} {{\eta _c}} \\[3pt] {{\delta _e}} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[3pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c@{\quad}c} {{f_1}} & 0 \\[3pt] 0 & {{f_2}} \end{array} \right]\left[ \begin{array}{c} {\Psi ({\eta _c})} \\[3pt] {\Psi ({\delta _e})} \end{array} \right] \nonumber\\[6pt]
&\quad + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[3pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c} {{d_1}(t)} \\[3pt] {{d_2}(t)} \end{array} \right] \end{align}
Define  $ - \left[\! \begin{array}{cc} {{b_{11}}} & {{b_{12}}} \\[2pt] {{b_{21}}} & {{b_{22}}} \end{array} \!\right]\left[\! \begin{array}{c@{\quad}c} {1 - {f_1}} & 0 \\[2pt] 0 & {1 - {f_2}} \end{array} \!\right]\left[\! \begin{array}{c} {{\eta _c}} \\[2pt] {{\delta _e}} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[2pt] {{b_{21}}} & {{b_{22}}} \end{array} \!\right]\left[\! \begin{array}{c@{\quad}c} {{f_1}} & 0 \\[2pt] 0 & {{f_2}} \end{array} \!\right]\left[\! \begin{array}{c} {\Psi ({\eta _c})} \\[2pt] {\Psi ({\delta _e})} \end{array} \right] + \left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[2pt] {{b_{21}}} & {{b_{22}}} \end{array} \!\right] \left[\! \begin{array}{c} {{d_1}(t)} \\[2pt] {{d_2}(t)} \end{array} \!\right]$
as the integrated fault, recorded as d *, and the FFO is used to estimate the integrated fault and its derivative.
 \begin{equation}\left[ \begin{array}{c} {{\dot S}_V} \\[2pt] {{\dot S}_h} \end{array} \right] = \underbrace {\left[ \begin{array}{c} {f_V} \\[2pt] {f_h} \end{array} \right]-\left[ \begin{array}{c} {\dddot{V}_{\rm ref}} \\[5pt] {h_{\rm ref}}^{(4)} \end{array} \right] + \left[ \begin{array}{l} 3{\lambda _V}{{\ddot e}_V} + 3\lambda _V^2{{\dot e}_V} + \lambda _V^3{e_V} \\[3pt] 4{\lambda _h}{\dddot{e}_h} + 6\lambda _h^2{{\ddot e}_h} + 4\lambda _h^3{{\dot e}_h} + \lambda _h^4{e_h} \end{array} \right]}_W + \underbrace {\left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[2pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]\left[ \begin{array}{c} {{\eta _c}} \\[2pt] {{\delta _e}} \end{array} \right]}_{Bu} +\, {d^*}\end{equation}
Considering the input-output linearisation model and the above dynamic sliding mode equation, the integrated fault d * is estimated based on the FFO principle. The first-order observer can estimate the fault, but in the simulation results, the first-order observer is not very good. Therefore, the third-order observer is used to comprehensive fault and estimate and improve control performance. The designed third-order FFO is as follows:
 \begin{align} {{\dot z}_0} &= \left[ \begin{array}{c} {{{\dot z}_{01}}} \\ {{{\dot z}_{02}}} \end{array} \right] = \left[ \begin{array}{c} {{v_{01}}} \\ {{v_{02}}} \end{array} \right] + W + Bu \nonumber\\[8pt]
\left[ \begin{array}{c} {{v_{01}}} \\ {{v_{02}}} \end{array} \right]&= - {\lambda _{0,1}}\left[ \begin{array}{c@{\quad}c} {\left( {{z_{01}} - {S_V}} \right)} & 0 \\ 0 & {\left( {{z_{02}} - {S_h}} \right)} \end{array} \right]\nonumber\\[8pt]
&\quad- {\lambda _{0,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{4}}{{\left| {{z_{01}} - {S_V}} \right|}^{\frac{3}{4}}}} & 0 \\ 0 & {L_h^{\frac{1}{4}}{{\left| {{z_{02}} - {S_h}} \right|}^{\frac{3}{4}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({z_{01}} - {S_V})} \\[2pt] {{\rm{sign}}({z_{02}} - {S_h})} \end{array} \right] + \left[ \begin{array}{c} {{z_{11}}} \\[2pt] {{z_{12}}} \end{array} \right] \nonumber\\[8pt]
{{\dot z}_1} &= \left[ \begin{array}{c} {{{\dot z}_{11}}} \\ {{{\dot z}_{12}}} \end{array} \right] = \left[ \begin{array}{c} {{v_{11}}} \\ {{v_{12}}} \end{array} \right] \nonumber\\[8pt]
\left[ \begin{array}{c} {{v_{11}}} \\ {{v_{12}}} \end{array} \right]&= - {\lambda _{1,1}}\left[ \begin{array}{c@{\quad}c} {\left( {{z_{11}} - {v_{01}}} \right)} & 0 \\ 0 & {\left( {{z_{12}} - {v_{02}}} \right)} \end{array} \right]\nonumber\\[8pt]
&\quad - {\lambda _{1,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{3}}{{\left| {{z_{11}} - {v_{01}}} \right|}^{\frac{2}{3}}}} & 0 \\ 0 & {L_h^{\frac{1}{3}}{{\left| {{z_{12}} - {v_{02}}} \right|}^{\frac{2}{3}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({z_{11}} - {v_{01}})} \\[2pt] {{\rm{sign}}({z_{12}} - {v_{02}})} \end{array} \right] + \left[ \begin{array}{c} {{z_{21}}} \\[2pt] {{z_{22}}} \end{array} \right] \nonumber\\[8pt]
{{\dot z}_2} &= \left[ \begin{array}{c} {{{\dot z}_{21}}} \\ {{{\dot z}_{22}}} \end{array} \right] = \left[ \begin{array}{c} {{v_{21}}} \\ {{v_{22}}} \end{array} \right]\nonumber\\[8pt]
\left[ \begin{array}{c} {{v_{21}}} \\ {{v_{22}}} \end{array} \right]&= - {\lambda _{2,1}}\left[ \begin{array}{c@{\quad}c} {\left( {{z_{21}} - {v_{11}}} \right)} & 0 \\ 0 & {\left( {{z_{22}} - {v_{12}}} \right)} \end{array} \right]\nonumber\\[8pt]
&\quad - {\lambda _{2,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{2}}{{\left| {{z_{21}} - {v_{11}}} \right|}^{\frac{1}{2}}}} & 0 \\ 0 & {L_h^{\frac{1}{2}}{{\left| {{z_{22}} - {v_{12}}} \right|}^{\frac{1}{2}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({z_{21}} - {v_{11}})} \\[2pt] {{\rm{sign}}({z_{22}} - {v_{12}})} \end{array} \right] + \left[ \begin{array}{c} {{z_{31}}} \\[2pt] {{z_{32}}} \end{array} \right]\nonumber\\
{{\dot z}_3} &= \left[ \begin{array}{c} {{{\dot z}_{31}}} \\[2pt] {{{\dot z}_{32}}} \end{array} \right] = - {\lambda _{3,1}}\left[ \begin{array}{c@{\quad}c} {\left( {{z_{31}} - {v_{21}}} \right)} & 0 \\[2pt] 0 & {\left( {{z_{32}} - {v_{22}}} \right)} \end{array} \right]\nonumber\\[8pt]
&\quad - {\lambda _{3,2}}\left[ \begin{array}{c@{\quad}c} {{L_V}{{\left| {{z_{31}} - {v_{21}}} \right|}^{{q \over p}}}} & 0 \\[2pt] 0 & {{L_h}{{\left| {{z_{32}} - {v_{22}}} \right|}^{{q \over p}}}} \end{array} \right]\left[ \begin{array}{c} {{\rm{sign}}({z_{31}} - {v_{21}})} \\[2pt] {{\rm{sign}}({z_{32}} - {v_{22}})} \end{array} \right] \end{align}
where  ${z_0},{z_1},{z_2},{z_3}$
are the estimated values of
 $S,{d^{\ast}},{{\dot{d^{}}}^{\ast}},\ddot{d^{}}^{\ast}$
, respectively.
 $L_i\leq\|\dddot{d}^{\ast}_i\|, i=V,h, {\lambda _{0,1}},{\lambda _{0,2}},{\lambda _{1,1}},{\lambda _{1,2}}...,{L_V},{L_h}$
are the observer parameters.
 ${\lambda _0},{\lambda _1},{\lambda _2},{\lambda _3}$
meet the rule of
 $\left\{ {{\lambda _i}} \right\}_{i = 0}^\infty = 1.1,1.5,2,3,5,8,...$
(Reference Levant and Livne17).
4.1 Proof of stability
Consider there are observer gains  ${\lambda _{0,1}},{\lambda _{0,2}},{\lambda _{1,1}},{\lambda _{1,2}}...$
, normal numbers
 ${L_V},{L_h}$
, p, q, etc., so that the estimated state
 ${z_0},{z_1},{z_2},{z_3}$
of the observer can converge to
 $S,{d^{*}},{\dot{d^{}}^{*}},{\ddot{d^{}}^{*}}$
. The controller is designed as follows:
 \begin{align} \left[ \begin{array}{c} {{\eta _c}} \\[3pt] {{\delta _e}} \end{array} \right] &= - {\left[ \begin{array}{c@{\quad}c} {{b_{11}}} & {{b_{12}}} \\[3pt] {{b_{21}}} & {{b_{22}}} \end{array} \right]^{ - 1}}*\left( {\left[ \begin{array}{l} {f_V} + 3{\lambda _V}{{\ddot e}_V} + 3\lambda _V^2{{\dot e}_V} + \lambda _V^3{e_V} - {\dddot{V}_{\rm ref}} \\[5pt] {f_h} + 4{\lambda _h}{\dddot{e}_h} + 6\lambda _h^2{{\ddot e}_h} + 4\lambda _h^3{{\dot e}_h} + \lambda _h^4{e_h} - {h_{\rm ref}}^{(4)} \end{array} \right]} \right. \nonumber\\[8pt]
&\quad \left. { + \left[ \begin{array}{l} {k_{V1}}{\left| {{S_V}} \right|^{{\alpha _V}}}{\rm{sign}}({S_V}) + {k_{V2}}{\left| {{S_V}} \right|^{{\beta _V}}}{\rm{sign}}({S_V}) + {k_{V3}}{S_V} \\[5pt] {k_{h1}}{\left| {{S_h}} \right|^{{\alpha _h}}}{\rm{sign}}({S_h}) + {k_{h2}}{\left| {{S_h}} \right|^{{\beta _h}}}{\rm{sign}}({S_h}) + {k_{h3}}{S_h} \end{array} \right] + \left[ \begin{array}{c} {{z_{11}}} \\[5pt] {{z_{12}}} \end{array} \right]} \right) \end{align}
where  ${k_{V1}},{k_{V2}},{k_{V3}},{k_{h1}},{k_{h2}},{k_{h3}} \gt 0$
are the control parameters,
 ${\alpha _V} \gt 1$
,
 ${\alpha _h} \gt 1$
,
 $0 \lt {\beta _V} \lt 1$
,
 $0 \lt {\beta _h} \lt 1$
, and
 ${\rm{sign}}({S_V}),{\rm{sign}}({S_h})$
are the symbol functions. In order to verify the stability of the controller, consider the observation error of the observer
 ${e_0} = S - {z_0}$
,
 ${e_1} = {d^{*}} - {z_1}$
,
 ${e_2} = {\dot{d^{}}^{*}} - {z_2}$
,
 ${e_3} = {\ddot{d^{}}^{*}} - {z_3}$
.
Finding the first derivative of the above observation error can be obtained as follows:
 \begin{align} {{\dot e}_0} &= \dot S - {{\dot z}_0} \nonumber\\[3pt]
&=W + Bu + {d^{*}} - \left( {{v_0} + W + Bu} \right) \nonumber\\[3pt]
&={\lambda _{0,1}}\left[ \begin{array}{c@{\quad}c} {{e_{01}}} & 0 \\[3pt] 0 & {{e_{02}}} \end{array} \right] - {\lambda _{0,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{4}}{{\left| {{e_{01}}} \right|}^{\frac{3}{4}}}} & 0 \\[3pt] 0 & {L_h^{\frac{1}{4}}{{\left| {{e_{02}}} \right|}^{\frac{3}{4}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({e_{01}})} \\[3pt] {{\rm{sign}}({e_{02}})} \end{array} \right] + {d^{*}} - \left[ \begin{array}{c} {{z_{11}}} \\[3pt] {{z_{12}}} \end{array} \right] \nonumber\\[3pt]
& ={\lambda _{0,1}}\left[ \begin{array}{c@{\quad}c} {{e_{01}}} & 0 \\[3pt] 0 & {{e_{02}}} \end{array} \right] - {\lambda _{0,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{4}}{{\left| {{e_{01}}} \right|}^{\frac{3}{4}}}} & 0 \\[3pt] 0 & {L_h^{\frac{1}{4}}{{\left| {{e_{02}}} \right|}^{\frac{3}{4}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({e_{01}})} \\[3pt] {{\rm{sign}}({e_{02}})} \end{array} \right] + {e_1} \end{align}
 \begin{align} {{\dot e}_1} &= {{\dot d}^{*}} - {{\dot z}_1} \nonumber\\[3pt]
& ={\lambda _{1,1}}\left[ \begin{array}{c@{\quad}c} {{e_{11}}} & 0 \\[3pt] 0 & {{e_{12}}} \end{array} \right] - {\lambda _{1,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{3}}{{\left| {{e_{11}}} \right|}^{\frac{2}{3}}}} & 0 \\[3pt] 0 & {L_h^{\frac{1}{3}}{{\left| {{e_{12}}} \right|}^{\frac{2}{3}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({e_{11}})} \\[3pt] {{\rm{sign}}({e_{12}})} \end{array} \right] + {{\dot d}^{*}} - \left[ \begin{array}{c} {{z_{21}}} \\[3pt] {{z_{22}}} \end{array} \right] \nonumber\\[3pt]
& ={\lambda _{1,1}}\left[ \begin{array}{c@{\quad}c} {{e_{11}}} & 0 \\[3pt] 0 & {{e_{12}}} \end{array} \right] - {\lambda _{1,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{3}}{{\left| {{e_{11}}} \right|}^{2/3}}} & 0 \\[3pt] 0 & {L_h^{\frac{1}{3}}{{\left| {{e_{12}}} \right|}^{\frac{2}{3}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({e_{11}})} \\[3pt] {{\rm{sign}}({e_{12}})} \end{array} \right] + {e_2} \end{align}
 \begin{align} {{\dot e}_2} & = {{\ddot d}^{*}} - {{\dot z}_2} \nonumber\\[3pt]
& ={\lambda _{2,1}}\left[ \begin{array}{c@{\quad}c} {{e_{21}}} & 0 \\[3pt] 0 & {{e_{22}}} \end{array} \right] - {\lambda _{2,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{2}}{{\left| {{e_{21}}} \right|}^{\frac{1}{2}}}} & 0 \\[3pt] 0 & {L_h^{\frac{1}{2}}{{\left| {{e_{22}}} \right|}^{\frac{1}{2}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({e_{21}})} \\[3pt] {{\rm{sign}}({e_{22}})} \end{array} \right] + {{\ddot d}^{*}} - \left[ \begin{array}{c} {{z_{31}}} \\[3pt] {{z_{32}}} \end{array} \right] \nonumber\\[3pt]
&={\lambda _{2,1}}\left[ \begin{array}{c@{\quad}c} {{e_{21}}} & 0 \\[3pt] 0 & {{e_{22}}} \end{array} \right] - {\lambda _{2,2}}\left[ \begin{array}{c@{\quad}c} {L_V^{\frac{1}{2}}{{\left| {{e_{21}}} \right|}^{\frac{1}{2}}}} & 0 \\[3pt] 0 & {L_h^{\frac{1}{2}}{{\left| {{e_{22}}} \right|}^{\frac{1}{2}}}} \end{array} \right] \cdot \left[ \begin{array}{c} {{\rm{sign}}({e_{21}})} \\[3pt] {{\rm{sign}}({e_{22}})} \end{array} \right] + {e_3} \end{align}
 \begin{align} {{\dot e}_3} &= {\dddot{d^{}}^*} - {{\dot z}_3} \nonumber\\[3pt]
& ={\lambda _{3,1}}\left[ \begin{array}{c@{\quad}c} {{e_{31}}} & 0 \\[3pt] 0 & {{e_{32}}} \end{array} \right] - {\lambda _{3,2}}\left[ \begin{array}{c@{\quad}c} {{L_V}{{\left| {{e_{31}}} \right|}^{{q \over p}}}} & 0 \\[3pt] 0 & {{L_h}{{\left| {{e_{32}}} \right|}^{{q \over p}}}} \end{array} \right]\left[ \begin{array}{c} {{\rm{sign}}({e_{31}})} \\[3pt] {{\rm{sign}}({e_{32}})} \end{array} \right] + {\dddot{d^{}}^*} \end{align}
By selecting the appropriate observer gain, the observation error can converge to 0 within a finite time t l; that is, the  ${z_0},{z_1},{z_2},{z_3}$
online estimation of
 $S,{d^*},{\dot d^{*}},{\ddot d^{*}}$
is achieved. Select the Lyapunov function,
 $V = 0.5{S^T}S$
, then
 \begin{align} \dot V &= {S^T}\dot S={S^T}\left( {W + Bu + {d^{*}}} \right) \nonumber\\[3pt]
&={S^T}\left( { - \left[ \begin{array}{l} {k_{V1}}{\left| {{S_V}} \right|^{{\alpha _V}}}{\rm{sign}}({S_V}) + {k_{V2}}{\left| {{S_V}} \right|^{{\beta _V}}}{\rm{sign}}({S_V}) + {k_{V3}}{S_V} \\[5pt] {k_{h1}}{\left| {{S_h}} \right|^{{\alpha _h}}}{\rm{sign}}({S_h}) + {k_{h2}}{\left| {{S_h}} \right|^{{\beta _h}}}{\rm{sign}}({S_h}) + {k_{h3}}{S_h} \end{array} \right] - \left[ \begin{array}{c} {{z_{11}}} \\[5pt] {{z_{12}}} \end{array} \right] + {d^{*}}} \right) \nonumber\\[8pt]
&={S^T}\left( { - \left[ \begin{array}{l} {k_{V1}}{\left| {{S_V}} \right|^{{\alpha _V}}}{\rm{sign}}({S_V}) + {k_{V2}}{\left| {{S_V}} \right|^{{\beta _V}}}{\rm{sign}}({S_V}) + {k_{V3}}{S_V} \\[5pt] {k_{h1}}{\left| {{S_h}} \right|^{{\alpha _h}}}{\rm{sign}}({S_h}) + {k_{h2}}{\left| {{S_h}} \right|^{{\beta _h}}}{\rm{sign}}({S_h}) + {k_{h3}}{S_h} \end{array} \right] + {e_1}} \right) \end{align}
1. When the observation error is zero,
let  ${k_1} = \min \{ {k_{V1}},{k_{h1}}\} ;{k_2} = \min \{ {k_{V2}},{k_{h2}}\} ;{k_3} = \min \{ {k_{V3}},{k_{h3}}\} $
,
 ${\alpha _1} = {\rm{min}}\{ {\alpha _V},{\alpha _h}\} $
,
 ${\beta _1} = {\rm{min}}\{ {\beta _V},{\beta _h}\} $
and get
 \begin{equation}\dot V \le - {k_1}{({\left| {{S_V}} \right|^2} + {\left| {{S_h}} \right|^2})^{\frac{{{\alpha _1} + 1}}{2}}} - {k_2}{({\left| {{S_V}} \right|^2} + {\left| {{S_h}} \right|^2})^{\frac{{{\beta _1} + 1}}{2}}} - {k_3}({\left| {{S_V}} \right|^2} + {\left| {{S_h}} \right|^2})\end{equation}
let  $k = \min \{ {k_1},{k_2},{k_3}\} $
, because
 ${\beta _1} \lt 1$
, then
 $\frac{{{\beta _1} + 1}}{2}=\min \{ \frac{{{\beta _1} + 1}}{2},\frac{{{\alpha _1} + 1}}{2},1\} $
and get
 \begin{equation}\dot V \le - k{(0.5{s^T}s)^{\frac{{{\beta _1} + 1}}{2}}}\end{equation}
2. When the observation error is not zero
 \begin{align} & \dot V={S^T}\left( { - \left[ \begin{array}{l} {k_{V2}}{\left| {{S_V}} \right|^{{\beta _V}}}{\rm{sign}}({S_V}) + {k_{V3}}{S_V} \\[5pt]
{k_{h2}}{\left| {{S_h}} \right|^{{\beta _h}}}{\rm{sign}}({S_h}) + {k_{h3}}{S_h} \end{array} \right]} \right) \nonumber\\[8pt]
& \qquad - {S^T}\left( {\left[ \begin{array}{c} {{k_{V1}}} \\[5pt]
{{k_{h1}}} \end{array} \right] - \left[ \begin{array}{cc} {{e_{11}}} & 0 \\[5pt]
0 & {{e_{12}}} \end{array} \right]{{\left[ \begin{array}{cc} {{{\left| {{S_V}} \right|}^{{\alpha _V}}}{\rm{sign}}({S_V})} & 0 \\[5pt]
0 & {{{\left| {{S_h}} \right|}^{{\alpha _h}}}{\rm{sign}}({S_h})} \end{array} \right]}^{ - 1}}} \right)\left[ \begin{array}{l} {{{\left| {{S_V}} \right|}^{{\alpha _V}}}{\rm{sign}}({S_V})} \nonumber\\[5pt]
{{{\left| {{S_h}} \right|}^{{\alpha _h}}}{\rm{sign}}({S_h})} \end{array} \right] \\
& ={S^T}\left( { - \left[ \begin{array}{c} {k_{V1}}{\left| {{S_V}} \right|^{{\alpha _V}}}{\rm{sign}}({S_V}) + {k_{V3}}{S_V} \\[5pt]
{k_{h1}}{\left| {{S_h}} \right|^{{\alpha _h}}}{\rm{sign}}({S_h}) + {k_{h3}}{S_h} \end{array} \right]} \right) \nonumber \\[8pt]
& \quad - {S^T}\left( {\left[ \begin{array}{c} {{k_{V2}}} \\ [5pt]
{{k_{h2}}} \end{array} \right] - \left[ \begin{array}{cc} {{e_{11}}} & 0 \\[5pt]
0 & {{e_{12}}} \end{array} \right]{{\left[ \begin{array}{cc} {{{\left| {{S_V}} \right|}^{{\beta _V}}}{\rm{sign}}({S_V})} & 0 \\[5pt]
0 & {{{\left| {{S_h}} \right|}^{{\beta _h}}}{\rm{sign}}({S_h})} \end{array} \right]}^{ - 1}}} \right)\left[ \begin{array}{c} {{{\left| {{S_V}} \right|}^{{\beta _V}}}{\rm{sign}}({S_V})} \\[5pt]
{{{\left| {{S_h}} \right|}^{{\beta _h}}}{\rm{sign}}({S_h})} \end{array} \right] \end{align}
If  $\left( {\left[ \begin{array}{c} {{k_{V1}}} \\[5pt]
{{k_{h1}}} \end{array} \right] - \left[ \begin{array}{cc} {{e_{11}}} & \quad 0 \\
0 & \quad {{e_{12}}} \end{array} \right]{{\left[ \begin{array}{cc} {{{\left| {{S_V}} \right|}^{{\alpha _V}}}{\rm{sign}}({S_V})} & 0 \\[5pt]
0 & \quad {{{\left| {{S_h}} \right|}^{{\alpha _h}}}{\rm{sign}}({S_h})} \end{array} \right]}^{ - 1}}} \right)$
or
 $
\left( \left[ \begin{array}{c} {{k_{V2}}} \\[5pt]
{{k_{h2}}} \end{array} \right] - \left[ \begin{array}{cc} {{e_{11}}} & \quad 0 \\[5pt]
0 & \quad {{e_{12}}} \end{array} \right]{{\left[ \begin{array}{cc} {{{\left| {{S_V}} \right|}^{{\beta _V}}}{\rm{sign}}({S_V})} & \quad 0 \\[5pt]
0 & \quad {{{\left| {{S_h}} \right|}^{{\beta _h}}}{\rm{sign}}({S_h})} \end{array} \right]}^{ - 1}} \right)$
is greater than 0, remember
 \begin{equation}\dot V={S^T}\left( { - \left[ \begin{array}{l} {k_{V1}^{\prime}}{\left| {{S_V}} \right|^{{\alpha _V}}}{\rm{sign}}({S_V}) + {k_{V2}^{\prime}}{\left| {{S_V}} \right|^{{\beta _V}}}{\rm{sign}}({S_V}) + {k_{V3}}{S_V} \\[5pt]
{k_{h1}^{\prime}}{\left| {{S_h}} \right|^{{\alpha _h}}}{\rm{sign}}({S_h}) + {k_{h2}^{\prime}}{\left| {{S_h}} \right|^{{\beta _h}}}{\rm{sign}}({S_h}) + {k_{h3}}{S_h} \end{array} \right]} \right)\end{equation}
where  ${\rm{diag}}({k^{\prime}}_{V1},{k^{\prime}}_{h1}),{\rm{diag}}({k^{\prime}}_{V2},{k^{\prime}}_{h2})$
are positive definite matrixes, since the observation error is not zero, let
 ${\zeta _V} = \min \left\{ {{{\left| {{e_{11}}/{k_{V1}}} \right|}^{1/{\alpha _V}}},{{\left| {{e_{11}}/{k_{V2}}} \right|}^{1/{\beta _V}}}} \right\}$
,
 ${\zeta _h} = \min \left\{ {{{\left| {{e_{12}}/{k_{h1}}} \right|}^{1/{\alpha _V}}},{{\left| {{e_{12}}/{k_{h2}}} \right|}^{1/{\beta _V}}}} \right\}$
.
A:  ${\zeta _V} \lt \left| {{S_V}} \right|,{\zeta _h} \lt \left| {{S_h}} \right|$
It can be seen from the above analysis that the system can converge in a finite time. Based on geometric homogeneity, the speed tracking error converges to the  ${\zeta _V}$
domain of the velocity sliding surface in a finite time, and altitude tracking error converges to the
 ${\zeta _h}$
domain of the height sliding mode in a finite time. The tracking error e 1 converges to 0 in t l, so the aircraft can stably track a given command for a limited time.
B:  ${\zeta _V}=\left| {{S_V}} \right|,{\zeta _h}=\left| {{S_h}} \right|$
Case 1  ${S_V} = {\left| {{e_{11}}/{k_{V1}}} \right|^{1/{\alpha _V}}},{S_h} = {\left| {{e_{12}}/{k_{h1}}} \right|^{1/{\alpha _V}}}$
 \begin{align}&\begin{array}{l} \dot V={S^T}\left( { - \left[ \begin{array}{l}{k_{V2}}{\left| {{S_V}} \right|^{{\beta _V}}}{\rm{sign}}({S_V}) + {k_{V3}}{S_V}\\[5pt]
{k_{h2}}{\left| {{S_h}} \right|^{{\beta _h}}}{\rm{sign}}({S_h}) + {k_{h3}}{S_h}\end{array} \right]} \right)\end{array}\nonumber\\[5pt]
& = - {k_{V2}}{\left| {{e_{11}}/{k_{V1}}} \right|^{\frac{{{\beta _V} + 1}}{{{\alpha _V}}}}}{\rm{sign}}({S_V}) - {k_{V3}}{\left| {{e_{11}}/{k_{V1}}} \right|^{\frac{2}{{{\alpha _V}}}}} - {k_{h2}}{\left| {{e_{12}}/{k_{h1}}} \right|^{\frac{{{\beta _V} + 1}}{{{\alpha _V}}}}}{\rm{sign}}({S_h})\nonumber\\
& - {k_{h3}}{\left| {{e_{12}}/{k_{h1}}} \right|^{\frac{2}{{{\alpha _V}}}}}\nonumber\\[5pt]
& = - {k_{V2}}{\left| {{e_{11}}} \right|^{\frac{{{\beta _V} + 1}}{{{\alpha _V}}}}} \cdot {k_{V1}}^{ - \frac{{{\beta _V} + 1}}{{{\alpha _V}}}} - {k_{V3}}{\left| {{e_{11}}} \right|^{\frac{2}{{{\alpha _V}}}}} \cdot {k_{V1}}^{ - \frac{2}{{{\alpha _V}}}} - {k_{h2}}{\left| {{e_{12}}} \right|^{\frac{{{\beta _V} + 1}}{{{\alpha _V}}}}} \cdot {k_{h1}}^{ - \frac{{{\beta _V} + 1}}{{{\alpha _V}}}}\nonumber\\
& - {k_{h3}}{\left| {{e_{12}}} \right|^{\frac{2}{{{\alpha _V}}}}} \cdot {k_{h1}}^{ - \frac{2}{{{\alpha _V}}}}\end{align}
Case 2  ${S_V} = {\left| {{e_{11}}/{k_{V2}}} \right|^{1/{\beta _V}}},{S_h} = {\left| {{e_{12}}/{k_{h2}}} \right|^{1/{\beta _V}}}$
 \begin{align} & \dot V={S^T}\left( { - \left[ \begin{array}{c} {k_{V2}}{\left| {{S_V}} \right|^{{\beta _V}}}{\rm{sign}}({S_V}) + {k_{V3}}{S_V} \\[5pt]
{k_{h2}}{\left| {{S_h}} \right|^{{\beta _h}}}{\rm{sign}}({S_h}) + {k_{h3}}{S_h} \end{array} \right]} \right)\nonumber \\[5pt]
& = - {k_{V2}}{\left| {{e_{11}}} \right|^{{{{\alpha_V} + 1} \over {{\beta_V}}}}} \cdot {k_{V2}}^{ - {{{\alpha_V} + 1} \over {{\beta_V}}}} - {k_{V3}}{\left| {{e_{11}}} \right|^{{2 \over {{\beta_V}}}}} \cdot {k_{V2}}^{ - {2 \over {{\beta_V}}}} - {k_{h2}}{\left| {{e_{12}}} \right|^{{{{\alpha_V} + 1} \over {{\beta_V}}}}} \cdot {k_{h2}}^{ - {{{\alpha_V} + 1} \over {{\beta_V}}}}\nonumber\\
& \quad - {k_{h3}}{\left| {{e_{12}}} \right|^{{2 \over {{\beta_V}}}}} \cdot {k_{h2}}^{ - {2 \over {{\beta_V}}}} \end{align}
Obviously, based on the above formula, the system can converge to  ${\zeta _V}=\left| {{S_V}} \right|,{\zeta _h}=\left| {{S_h}} \right|$
in a finite time. Due to the convergence of e 1 in a finite time, the aircraft can stably track a given command for a limited time.
C:  ${\zeta _V} \gt \left| {{S_V}} \right|,{\zeta _h} \gt \left| {{S_h}} \right|$
From the analysis in B, it is known that the boundary  ${\zeta _V}=\left| {{S_V}} \right|,{\zeta _h}=\left| {{S_h}} \right|$
of
 $\dot V$
is negative, therefore
 $\left| {{S_V}} \right|,\left| {{S_h}} \right|$
monotonically decreasing; that is, the state of the system on the boundary can enter the attraction domain
 ${\zeta _V} \ge \left| {{S_V}} \right|,{\zeta _h} \ge \left| {{S_h}} \right|$
. So the system can track the reference command and is robust for actuator fault in finite time under the control law designed in this paper.
5.0 SIMULATION ANALYSIS
In this section, simulation results are presented with MATLAB 2014b. The aircraft cruises at 33,530m altitude with the flight speed of 4,590m/s. The command values of flight altitude and velocity are 33,588 and 4,630m/s, respectively. Input saturation: ${\eta _c} \le 1$
,
 $\left| {{\delta _e}} \right| \le 30^\circ $
; parametric uncertainties:
 $\left| {{\Delta _{( \bullet )}}} \right| \le 0.01$
; disturbance:
 ${d_1}(t)=0.05 + 0.01\sin (0.2{t})$
,
 ${d_2}(t) = 0.06 + 0.03\sin (0.4{t})$
. The simulation parameters of sliding mode are selected as
 ${\lambda _V} = 0.5$
,
 ${\lambda _h} = 0.5$
,
 ${k_{V1}} = 0.8$
,
 ${k_{V2}} = 0.2$
,
 ${k_{V3}} = 0.2$
,
 ${k_{h1}} = 2.8$
,
 ${k_{h2}} = 0.2$
,
 ${k_{h3}} = 0.2$
,
 ${\alpha _v} = 0.5$
,
 ${\alpha _h} = 0.5$
,
 ${\beta _v} = 1.5$
,
 ${\beta _h} = 1.5$
.
Case 1: Gain loss fault
In order to verify the efficiency of the fault-tolerant control based on the FFO proposed in this paper, when  $t \ge 15s$
, the gain loss faults of the control efficiency are considered as:
 ${f_1}=1;{f_{e1}}=0.5;{f_{e2}}=0.8$
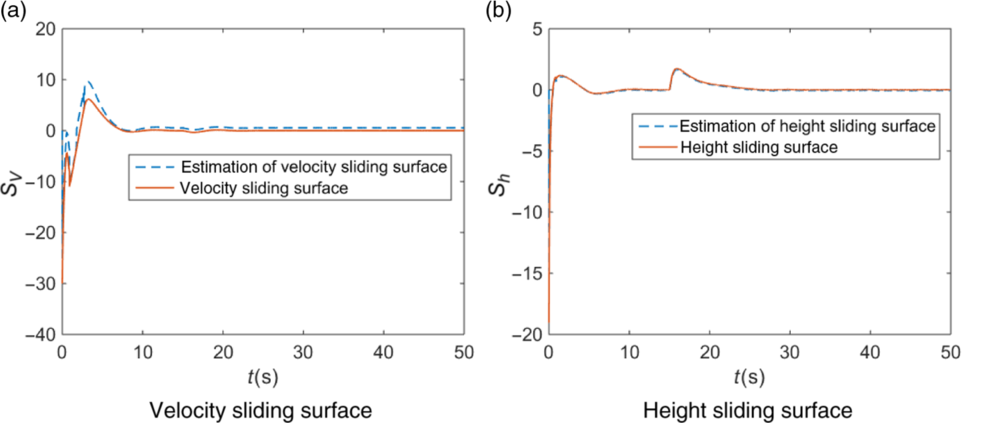
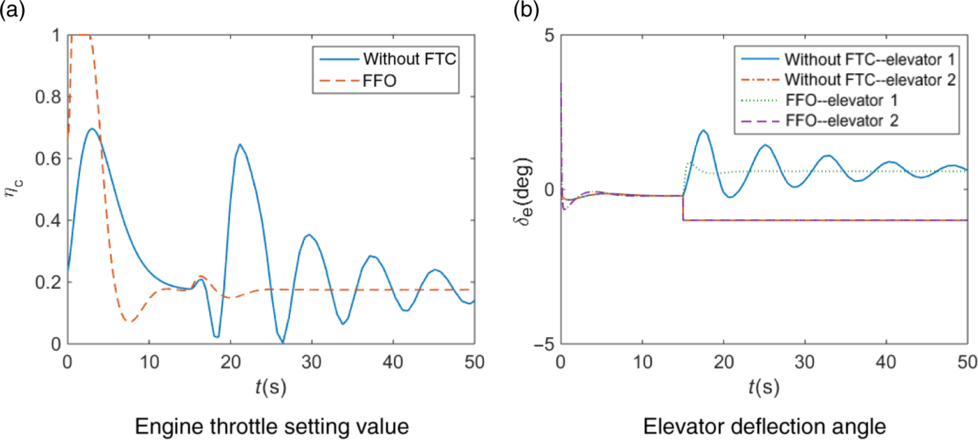
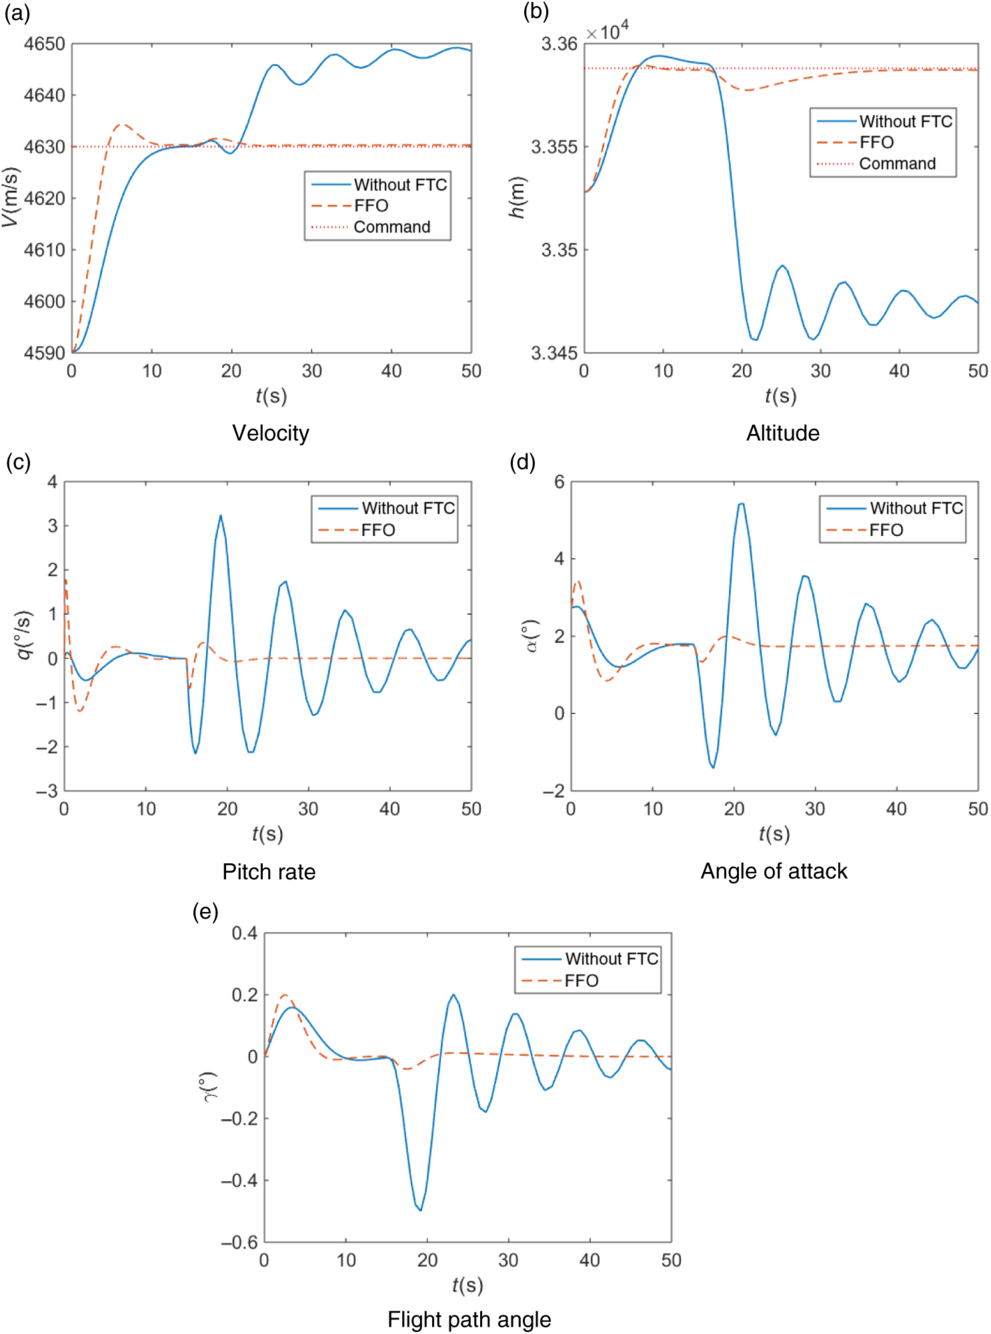
, Simulation results are shown in Figs 3, 4 and 5.
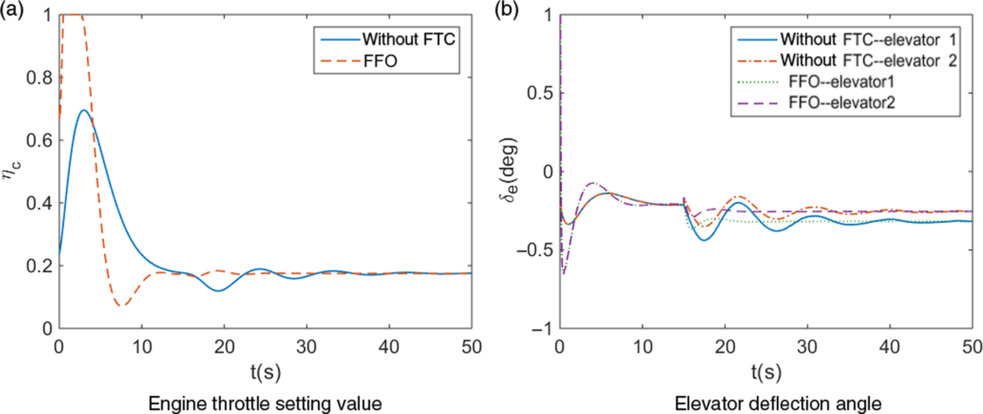
Control input under gain loss fault.

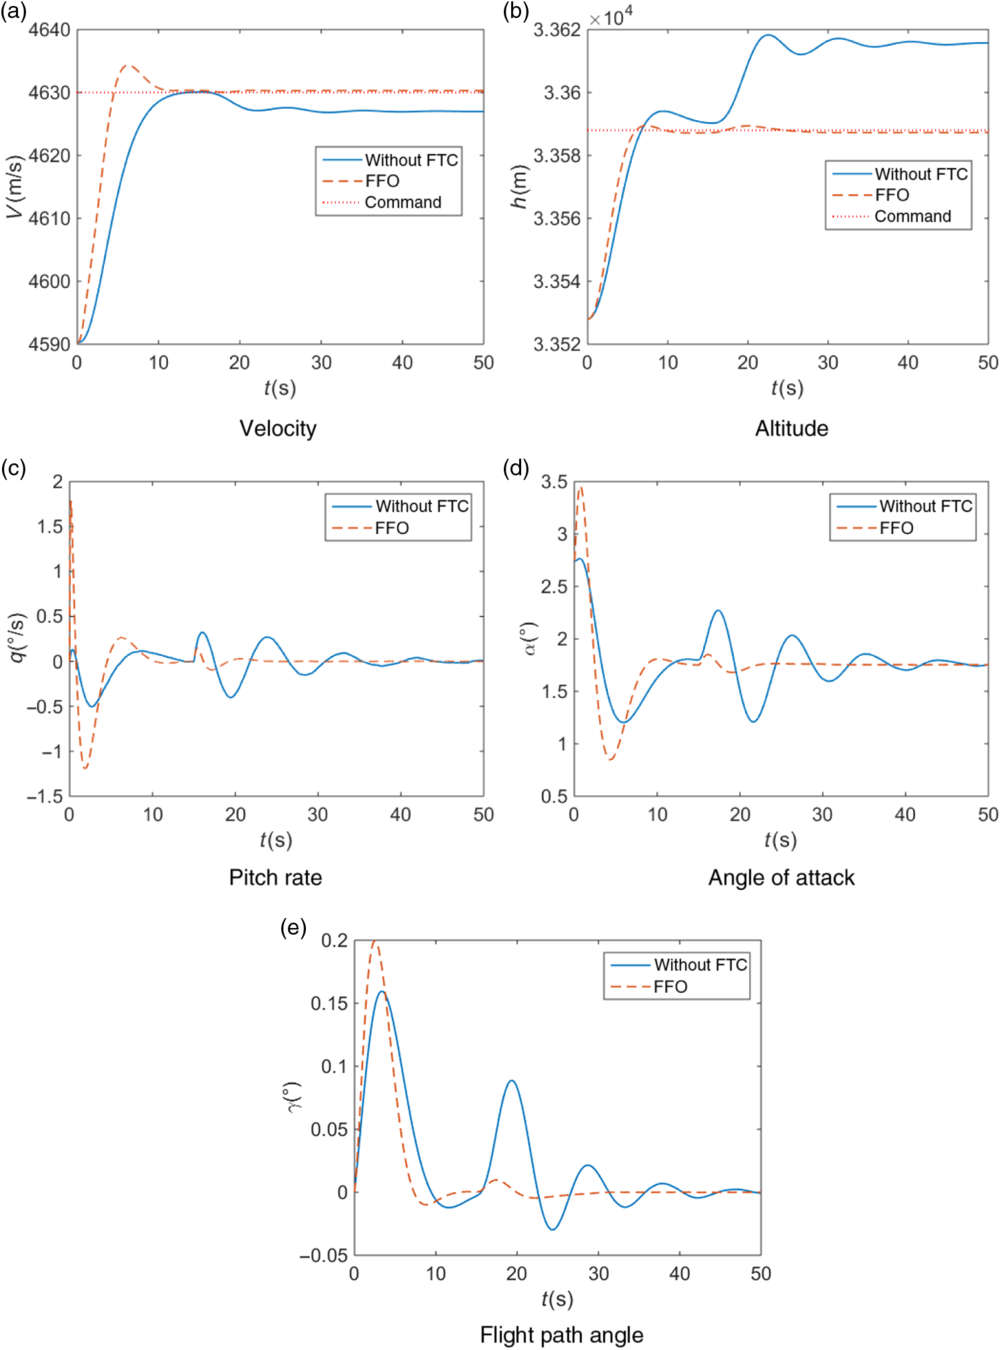
State responses under gain loss fault.

Sliding surface under gain loss fault.

It can be seen from the simulation results shown in Fig. 3 that after a gain loss fault occurs, the control input with FTC can change to a new steady-state value. The 1-th elevator deflection angle is adjusted from about −0.2° to −0.3°, the 2-th elevator deflection angle is adjusted from about −0.2° to −0.25° in about 5s. However, the control input without FTC cannot be stabilised quickly.
The state responses are shown in Fig. 4. It shows that the controller with FFO can make the state of hypersonic vehicle more stable than the controller without FTC. After 15s, the controller with FFO can make the state quickly stabilise, and the time to process the fault is about 5s. But under the control of the method without FTC, the velocity and altitude have greatly deviated. The pitch rate, angle-of-attack and flight path angle cannot be stabilised within the simulation time.
Figure 5 shows the sliding surface under gain loss fault, along with the occurrence of the fault at 15s. The sliding surface S V and S h dynamically change. z 01 and z 02 can estimate S V and S h in real time.
Case 2: Stuck fault
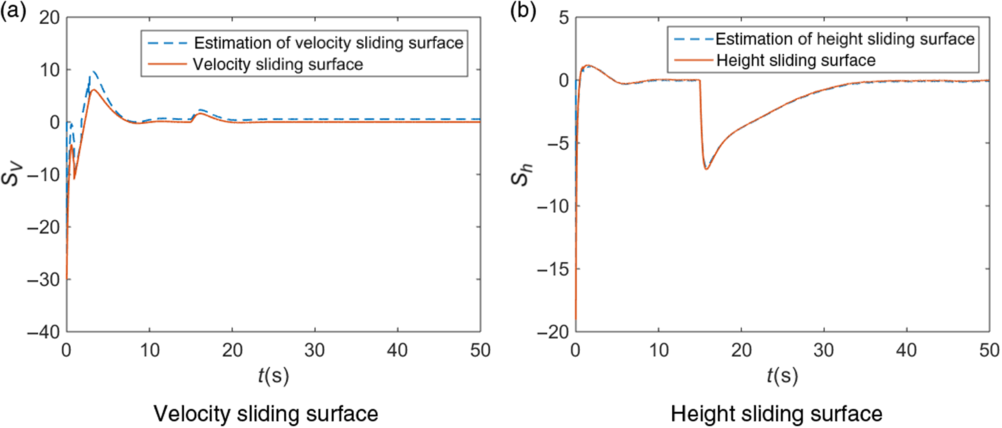
In addition to the gain loss fault, we also do a simulation experiment on the stuck fault. The 2-th elevator has stuck at −1° at 15s. Simulation results are shown in Figs 6, 7 and 8.
Control input under stuck fault.

State responses under stuck fault.

Sliding surface under stuck fault.

Figure 6 shows that after a stuck fault occurs at 15s, the 2-th elevator stuck at −1°, the 1th elevator deflection angle is adjusted from −0.2° to 0.8° to compensate for the impact of the 2-th elevator. However, the jitter of the controller without FTC is very large, that is, the blue curve in Fig 6(b).
Figure 7 shows the state responses under stuck fault, and the controller with FFO can make the state of the hypersonic vehicle stable. But the controller curve without FTC is divergent. The speed and altitude have greatly deviated. The pitch rate, angle-of-attack and flight path angle all cannot be stabilised within the simulation time.
Figure 8 shows the sliding surface under stuck fault. Similar to Fig 5, along with the occurrence of stuck fault at 15s, z 01 and z 02 can estimate S V and S h in real time.
6.0 CONCLUSION
This paper considers the fault-tolerant control of the longitudinal model of a hypersonic vehicle in the case of actuator gain loss fault and stuck fault. Firstly, we design an input-output linearisation model that considers parameter uncertainty, control input saturation, disturbance and faults. Then, in order to improve the efficiency of fault processing, a fast fault observer is obtained, which can estimate the integrated fault in real time. Finally, the simulation results are compared with the methods without fault-tolerant control. The main problems to be solved include: (1) The controller takes control input saturation, disturbance, parametric uncertainties and actuator faults into consideration; (2) It can quickly detect the integrated fault and compensate so that the fault can be processed at the first time; (3) It can simultaneously address actuator gain loss fault and stuck fault.
Further research work includes two aspects. Firstly, other types of fault, such as sensor fault and structure fault should be considered, and other types of actuator fault, such as floating fault and actuator fault with unknown structure, should also be considered. Furthermore, in practice, it is difficult to accurately measure the state quantity of a hypersonic vehicle, which causes measurement errors. Therefore, in the future research, it is necessary to design an observer for the unknown state of the system to achieve stable output feedback tracking of the aircraft under some unknown conditions.
ACKNOWLEDGEMENTS
This work was supported in part by Postgraduate Research and Practice Innovation Program of Jiangsu Province [Item Number: KYCX18_0303] and the National Natural Science Foundation of China (61673209).