



1. Introduction
In this paper, we are concerned with the classical competitive Lotka-Volterra system with diffusion
 \begin{equation} \left\{\begin{array}{@{}ll} \partial_tu=\partial_{xx}u+(1-u-k_1v)u,\\ \partial_tv=d\,\partial_{xx}v+r(1-v-k_2u)v, \end{array} \right.x\in\mathbb{R} \end{equation}
where  $k_1$,
 $k_2$,
 $r$,
 $d$ are positive constants and
 $u(x,t)$,
 $v(x,t)$ denote the population density of two competitive species that are nonnegative.
To begin with this paper, we recall that, as stated in [Reference Morita and Tachibana18], the solutions  $(u(t),v(t))$ of (1.1) without diffusion exhibit the following asymptotic behaviour as
 $t\rightarrow +\infty$:
(i) if
 $0< k_1<1< k_2$, then $(u(t),v(t))\rightarrow (1,0)$ ($u$ survives);
(ii) if
$0< k_2<1< k_1$, then $(u(t),v(t))\rightarrow (0,1)$ ($v$ survives);(iii) if
$k_1$, $k_2>1$, then $(u(t),v(t))\rightarrow (1,0)$ or $(u(t),v(t))\rightarrow (0,1)$ depending on the initial condition (strong competition and bistability);(iv) if
$0< k_1,k_2<1$, then $(u(t),v(t))$ converges to the positive equilibrium (weak competition, $u$ and $v$ coexist).


Here, we only consider the relative problems under the weak competition case (iv):  $0< k_1,k_2<1.$ In this case, the above system has four non-negative equilibria that are
 $(0,0)$,
 $(1,0)$,
 $(0,1)$ and
 $(({1-k_1}/{1-k_1k_2}), ({1-k_2}/{1-k_1k_2}))$.
A large number of papers focus on the study of spreading phenomena of system (1.1) under the cases (i)–(iv), such as [Reference Alhasanat and Ou1–Reference Alhasanat and Ou3, Reference Girardin and Lam6, Reference Hou and Leung7, Reference Lewis, Li and Weinberger9–Reference Ma, Chen, Yue and Han14, Reference Tang and Fife21, Reference Yue, Han, Tao and Ma27] and references therein, which is a significant and particularly interesting issue in reaction-diffusion systems. The existence of travelling wave fronts is an important part of this study. For (1.1), if the vector function  $(u(x,t),v(x,t))=(\phi (\xi ),\psi (\xi ))$ (
 $\xi =x+ct$) satisfies
 \begin{equation} \left\{\begin{array}{@{}ll} \phi''-c\phi'+(1-\phi-k_1\psi)\phi=0,\\ d\psi''-c\psi'+r(1-\psi-k_2\phi)\psi=0, \end{array} \right. \end{equation}
with
 \begin{equation} \lim\limits_{\xi\rightarrow-\infty}(\phi(\xi),\psi(\xi))=(0,1),\qquad \lim\limits_{\xi\rightarrow+\infty}(\phi(\xi),\psi(\xi))=\left(\frac{1-k_1}{1-k_1k_2}, \frac{1-k_2}{1-k_1k_2}\right), \end{equation}
we call it the travelling wave solution of (1.1) connecting  $(0,1)$ and
 $(({1-k_1}/{1-k_1k_2}),({1-k_2}/{1-k_1k_2}))$. If
 $\phi$ is increasing and
 $\psi$ is decreasing, then we call it the travelling wave front of (1.1). In the sequel, without special statements, the travelling wave front of (1.1) as we mention is the monotone solution to (1.2)–(1.3).
Since (1.1) can be changed into a cooperative system by a simple transform, which is given in the following, then from [Reference Li, Weinberger and Lewis11, Reference Volpert, Volpert and Volpert22], as we know, for wave propagation, there is always a minimal speed  $c_{\min }\geqslant 0$ and the spreading speed is identical to the minimum wave speed. Standard linearization near the equilibrium point
 $(0,1)$ gives that the minimal speed
 $c_{\min }$ of travelling wave front satisfies
 $c_{\min }\geqslant c_0:=2\sqrt {1-k_1}$, where
 $c_0$ is always called the critical speed. And Lam et al. in [Reference Lam, Salako and Wu8, Reference Liu, Liu and Lam12] also pointed out
 $c_{\min }\geqslant c_0$. As introduced in [Reference Alhasanat and Ou2, Reference Lewis, Li and Weinberger9], if
 $c_{\min }=c_0$, then we say that the minimal wave speed is linearly selected, otherwise, if
 $c_{\min }>c_0$, we say that the minimal wave speed is nonlinearly selected. In [Reference Lewis, Li and Weinberger9], Lewis et al. proved that when
 $0< d\leqslant 2$, then the minimal wave speed is linearly selected. Furthermore, when
 $d=1$, Hou and Leung in [Reference Hou and Leung7] proved there are travelling wave fronts of (1.1), if
 $r<1$,
 $c>2\sqrt {\frac {1-k_1}{1-k_1k_2}}$.
Whether the minimal wave speed is linearly selected or nonlinearly selected is an important problem in the classical competitive Lotka-Volterra system with diffusion. In the case (i), for travelling wave fronts of (1.1) connecting  $(0,1)$ and
 $(1,0)$, the speed selection problem is called Hosono's conjecture, and there are many excellent works on the linear or nonlinear selection, for example, see [Reference Alhasanat and Ou1–Reference Alhasanat and Ou3, Reference Li, Weinberger and Lewis11, Reference Ma, Chen, Yue and Han14, Reference Yue, Han, Tao and Ma27] and references therein. From the above statements, there are a few of results on the linear or nonlinear determinacy of the minimal wave speed of travelling wave fronts of (1.1) connecting
 $(0,1)$ and
 $(({1-k_1}/{1-k_1k_2}),({1-k_2}/{1-k_1k_2}))$. Thus, in this paper, we will give the regions of parameters in (1.1) to insure the linear or nonlinear selection, which are quite different from the conclusions in [Reference Alhasanat and Ou1–Reference Alhasanat and Ou3, Reference Li, Weinberger and Lewis11, Reference Ma, Chen, Yue and Han14, Reference Yue, Han, Tao and Ma27] and references therein, and increase the previously known parameter ranges that insure the linear selection in [Reference Lewis, Li and Weinberger9], and improve the existence results in [Reference Hou and Leung7]. In addition, a new nonlinear selection mechanism and a new sub-solution are given, which may be applicable for monostable travelling wave fronts of general monotone system.
Besides the existence, the stability of travelling wave fronts is also an important research content in reaction-diffusion theory, such as [Reference Faye and Holzer5, Reference Mei, Lin, Lin and So15–Reference Mei and Wang17, Reference Sattinger19, Reference Sattinger20, Reference Wang, Shi, Liu and Ma25, Reference Yu, Xu and Zhang26] and references therein. In [Reference Sattinger19, Reference Sattinger20], Sattinger gave the exponential stability of travelling wave fronts of the monostable scalar equation by constructing some weighted spaces and the spectrum-analysis. Then in [Reference Mei, Lin, Lin and So15], with the weighted energy method and  $L^{2}$-estimates, Mei et al. proved the exponential stability of travelling wave fronts of the monostable scalar equation with the delay for any
 $c$, which is larger than the critical speed of such equation. Moreover, in [Reference Mei, Ou and Zhao16], by the weighted energy method,
 $L^{1}$-estimates and
 $L^{2}$-estimates, Mei et al. obtained the exponential stability of the critical travelling wave front, while in [Reference Mei and Wang17], by weighted energy method and Fourier transformation, Mei and Wang gave optimal rates of convergence of travelling wave fronts. Recently, Yu et al. in [Reference Yu, Xu and Zhang26] discussed the exponential stability of travelling wave fronts connecting two equilibria on the axis of competitive system with nonlocal diffusion. In this paper, we finally establish the exponential stability of travelling wave fronts of (1.1) via the weighted energy method and
 $L^{2}$-estimates. In particular, as
 $k_2$ converges to
 $0$, then for any
 $c>c_0$, the exponential stability of travelling wave fronts with the speed
 $c$ is obtained.
The paper is organized as follows. We introduce some preliminaries in § 2. Then by constructing different kinds of pairs of super-sub solutions, the sufficient conditions on the linear or nonlinear speed selection are established in § 3. In the end, by constructing a suitable weighted function and some  $L^{2}$-estimates, we will prove the exponential stability of solutions to (1.2)–(1.3).
2. Preliminaries
In this section, we introduce some known results on the asymptotic behaviour and notations used in the following sections.
2.1. Asymptotic behavior
Let  $\tilde {u}=u$,
 $\tilde {v}=1-v$, then (1.1) is equivalent to, by dropping the tildes for convenience,
 \begin{equation} \left\{\begin{array}{@{}ll} \partial_tu=\partial_{xx}u+u(1-k_1-u+k_1v),\\ \partial_tv=d\,\partial_{xx}v+r(1-v)(k_2u-v), \end{array} \right.x\in\mathbb{R} \end{equation}
and correspondingly, (1.2)–(1.3) are changed into
 \begin{equation} \left\{\begin{array}{@{}ll} \phi''-c\phi'+\phi(1-k_1-\phi+k_1\psi)=0,\\ d\psi''-c\psi'+r(1-\psi)(k_2\phi-\psi)=0 \end{array} \right. \end{equation}
with
 \begin{equation} \lim\limits_{\xi\rightarrow-\infty}(\phi(\xi),\psi(\xi))=(0,0),\qquad\lim\limits_{\xi\rightarrow+\infty}(\phi(\xi),\psi(\xi))=(u^{{\ast}},v^{{\ast}}), \end{equation}
where  $u^{\ast }=\displaystyle \frac {1-k_1}{1-k_1k_2}$,
 $v^{\ast }=k_2\displaystyle \frac {1-k_1}{1-k_1k_2}=k_2 u^{\ast }$. Moreover, since
 \begin{equation*} 1-v^{{\ast}}=1-k_2u^{{\ast}}=1-k_2\frac{1-k_1}{1-k_1k_2}=\frac{1-k_2}{1-k_1k_2} :=\hat{v}^{{\ast}}>0, \end{equation*}
then  $(0,1)\notin [0,u^{\ast }]\times [0,v^{\ast }]$ and
 $(1,1)\notin [0,u^{\ast }]\times [0,v^{\ast }]$, which implies there is no other equilibria in
 $(0,u^{\ast })\times (0,v^{\ast })$.
By these changes, the cooperative system is obtained. Then from [Reference Li, Weinberger and Lewis11, Reference Volpert, Volpert and Volpert22], there is a minimal speed  $c_{\min }$, so that (2.2)–(2.3) has an increasing solution if and only if
 $c\geqslant c_{\min }$. Thus, if (2.2)–(2.3) has an increasing solution for
 $c\geqslant c_{\min }$, which is near
 $c_{\min }$, then (2.2)–(2.3) also has an increasing solution for all
 $\tilde {c}\geqslant c\geqslant c_{\min }$. In addition, travelling wave fronts of (1.1) mentioned above are travelling wave fronts of (2.1), which are increasing solutions to (2.2)–(2.3). In the following, we will investigate the existence and stability of increasing solutions to (2.2)–(2.3).
By letting  $\phi '=\hat {\phi }$ and
 $\psi '=\hat {\psi }$, (2.2) is equivalent to
 \begin{equation*} \left\{\begin{array}{@{}llll} \phi'=\hat{\phi},\\ \hat{\phi}'=c\hat{\phi}-(1-k_1-\phi+k_1\psi)\phi,\\ \psi'=\hat{\psi},\\ \hat{\psi}'=\dfrac{c}{d}\hat{\psi}-\dfrac{r}{d}(1-\psi)(k_2\phi-\psi). \end{array} \right. \end{equation*}
Linearizing it at  $(0,0,0,0)$ gives the following constant coefficient system
 \begin{equation*} \begin{pmatrix} \phi'_-\\ \hat{\phi}'_-\\ \psi'_-\\ \hat{\psi}'_- \end{pmatrix} = \begin{pmatrix} 0 & 1 & 0 & 0\\ -(1-k_1) & c & 0 & 0\\ 0 & 0 & 0 & 1\\ -\frac{rk_2}{d} & 0 & \frac{r}{d} & \frac{c}{d} \end{pmatrix} \begin{pmatrix} \phi_-\\ \hat{\phi}_-\\ \psi_-\\ \hat{\psi}_- \end{pmatrix}. \end{equation*}
The corresponding characteristic equation is
 \begin{equation} (\lambda^{2}-c\lambda+1-k_1)(d\lambda^{2}-c\lambda-r)=0. \end{equation}
Let
 \begin{equation*} \Delta_1(\lambda,c)=\lambda^{2}-c\lambda+1-k_1,\qquad \Delta_2(\lambda,c)=d\lambda^{2}-c\lambda-r. \end{equation*}
For  $c\geqslant c_0$, the positive roots of (2.4) are
 \begin{align*}
\lambda_1(c)&=\frac{c-\sqrt{c^{2}-4(1-k_1)}}{2},\quad
\lambda_2(c)=\frac{c+\sqrt{c^{2}-4(1-k_1)}}{2},\\
\lambda_3(c)&=\frac{c+\sqrt{c^{2}+4rd}}{2d},
\end{align*}
and obviously  $\lambda _1(c)\leqslant \lambda _2(c)$. Also, the solutions of (2.4) can be rewritten as
 \begin{equation*} c=\hat{c}_1(\lambda)=\lambda+\frac{1-k_1}{\lambda}\quad \mbox{or}\quad c=\hat{c}_2(\lambda)=d\lambda-\frac{r}{\lambda}. \end{equation*}
If  $d>1$,
 $\hat {c}_1(\lambda )$ could intersect
 $\hat {c}_2(\lambda )$ at the point
 $\hat {\lambda }=\sqrt {\frac {r+1-k_1}{d-1}}$. Meanwhile,
 \begin{equation*} \hat{c}_1(\hat{\lambda})=\hat{c}_2(\hat{\lambda}) =\sqrt{\frac{r+1-k_1}{d-1}}+(1-k_1)\sqrt{\frac{d-1}{r+1-k_1}}:=\hat{c}. \end{equation*}
Obviously,  $\hat {c}\geqslant c_0$ and
 $\hat {c}=c_0$ if and only if
 $d=2+({r}/{1-k_1})$. Then from [Reference Alhasanat and Ou2, Reference Girardin and Lam6, Reference Hou and Leung7, Reference Liu, Liu and Lam12, Reference Morita and Tachibana18, Reference Wang and Li23–Reference Wang, Shi, Liu and Ma25] and references therein, the increasing solution
 $(\phi ,\psi )$ has the following asymptotic behaviour as
 $\xi \rightarrow -\infty$:
 $\mathbf {Case\ 1}:$
 $0< d\leqslant 1$ with
 $c\geqslant c_0$ or
 $1< d<2+({r}/{1-k_1})$ with
 $c_0\leqslant c<\hat {c}$ (which implies
 $\lambda _1\leqslant \lambda _2<\lambda _3$),
if  $c>c_0$, then
 \begin{equation*} \begin{pmatrix} \phi\\ \psi \end{pmatrix} =C_1 \begin{pmatrix} -\Delta_2(\lambda_1,c)\\ rk_2 \end{pmatrix} \textrm{e}^{\lambda_1\xi} +C_2 \begin{pmatrix} -\Delta_2(\lambda_2,c)\\ rk_2 \end{pmatrix} \textrm{e}^{\lambda_2\xi} +h.o.t., \end{equation*}
where  $C_1\geqslant 0$, and
 $C_2>0\ (C_1=0)$;
if  $c=c_0$ (which implies
 $\lambda _1=\lambda _2$), then
 \begin{equation*} \begin{pmatrix} \phi\\ \psi \end{pmatrix} =C_1 \begin{pmatrix} -\Delta_2(\lambda_1,c)\\ rk_2 \end{pmatrix} \textrm{e}^{\lambda_1\xi} +C_2 \begin{pmatrix} \Delta_2(\lambda_1,c)\\ -rk_2 \end{pmatrix} \xi \textrm{e}^{\lambda_1\xi} +h.o.t., \end{equation*}
where  $C_2\geqslant 0$, and
 $C_1>0\ (C_2=0)$.
 $\mathbf {Case\ 2}:$
 $d>1$ and
 $c>\hat {c}$ (which implies
 $\lambda _1<\lambda _3<\lambda _2$),
 \begin{equation*} \begin{pmatrix} \phi\\ \psi \end{pmatrix} =C_1 \begin{pmatrix} -\Delta_2(\lambda_1,c)\\ rk_2 \end{pmatrix} \textrm{e}^{\lambda_1\xi} +C_2 \begin{pmatrix} \Delta_2(\lambda_2,c)\\ -rk_2 \end{pmatrix} \textrm{e}^{\lambda_2\xi} +C_3 \begin{pmatrix} 0\\ 1 \end{pmatrix} \textrm{e}^{\lambda_3\xi} +h.o.t., \end{equation*}
where  $C_1\geqslant 0$, and
 $C_2,\ C_3>0\ (C_1=0)$.
 $\mathbf {Case\ 3}:$
 $d>2+({r}/{1-k_1})$ and
 $c_0\leqslant c<\hat {c}$ (which implies
 $\lambda _3<\lambda _1\leqslant \lambda _2$),
if  $c>c_0$, then
 \begin{equation*} \begin{pmatrix} \phi\\ \psi \end{pmatrix} =C_1 \begin{pmatrix} \Delta_2(\lambda_1,c)\\ -rk_2 \end{pmatrix} \textrm{e}^{\lambda_1\xi} +C_2 \begin{pmatrix} \Delta_2(\lambda_2,c)\\ -rk_2 \end{pmatrix} \textrm{e}^{\lambda_2\xi} +C_3 \begin{pmatrix} 0\\ 1 \end{pmatrix} \textrm{e}^{\lambda_3\xi} +h.o.t., \end{equation*}
where  $C_1\geqslant 0$ and
 $C_2>0\ (C_1=0)$, and
 $C_3>0$;
if  $c=c_0$ (which implies
 $\lambda _1=\lambda _2$), then
 \begin{equation*} \begin{pmatrix} \phi\\ \psi \end{pmatrix} =C_1 \begin{pmatrix} \Delta_2(\lambda_1,c)\\ -rk_2 \end{pmatrix} \textrm{e}^{\lambda_1\xi} +C_2 \begin{pmatrix} -\Delta_2(\lambda_1,c)\\ rk_2 \end{pmatrix} \xi \textrm{e}^{\lambda_1\xi} +C_3 \begin{pmatrix} 0\\ 1 \end{pmatrix} \textrm{e}^{\lambda_3\xi} +h.o.t., \end{equation*}
where  $C_2\geqslant 0$, and
 $C_1>0\ (C_2=0)$, and
 $C_3>0$.
 $\mathbf {Case\ 4}:$
 $d>1$,
 $d\neq 2+({r}/{1-k_1})$ and
 $c=\hat {c}$ (which implies
 $\lambda _3=\lambda _1$ or
 $\lambda _3=\lambda _2$ and
 $\lambda _2>\lambda _1$),
if  $\lambda _3=\lambda _1$, then
 \begin{equation*} \begin{pmatrix} \phi\\ \psi \end{pmatrix} =C_1 \begin{pmatrix} 2d\lambda_3-c\\ -rk_2\xi \end{pmatrix} \textrm{e}^{\lambda_3\xi} +C_2 \begin{pmatrix} \Delta_2(\lambda_1,c)\\ -rk_2 \end{pmatrix} \textrm{e}^{\lambda_1\xi} +C_3 \begin{pmatrix} 0\\ 1 \end{pmatrix} \textrm{e}^{\lambda_3\xi} +h.o.t., \end{equation*}
where  $C_1\geqslant 0$, and
 $C_2, C_3>0\ (C_1=0)$,
 $2d\lambda _3-c=({d\lambda ^{2}_3+r}/{\lambda _3})>0$;
if  $\lambda _3=\lambda _2$, then
 \begin{equation*} \begin{pmatrix} \phi\\ \psi \end{pmatrix} =C_1 \begin{pmatrix} -\Delta_2(\lambda_1,c)\\ rk_2 \end{pmatrix} \textrm{e}^{\lambda_1\xi} +C_2 \begin{pmatrix} 2d\lambda_3-c\\ -rk_2\xi \end{pmatrix} \textrm{e}^{\lambda_3\xi} +h.o.t., \end{equation*}
where  $C_1\geqslant 0$, and
 $C_2>0\ (C_1=0)$;
 $\mathbf {Case\ 5}:$
 $d=2+({r}/{1-k_1})$ (which implies
 $\lambda _1=\lambda _2=\lambda _3$),
 \begin{equation*} \begin{pmatrix} \phi\\ \psi \end{pmatrix} =C_1 \begin{pmatrix} 2d\lambda_3-c\\ -rk_2\xi \end{pmatrix} \xi \textrm{e}^{\lambda_3\xi} +C_2 \begin{pmatrix} -2(2d\lambda_3-c)\xi\\ rk_2\xi^{2} \end{pmatrix} \textrm{e}^{\lambda_3\xi} +h.o.t., \end{equation*}
where  $C_2\geqslant 0$, and
 $C_1>0\ (C_2=0)$.
2.2. Notations and spaces
To prove the nonlinear stability, we introduce some notations and spaces used in this paper. Let  $a:=(a_1,a_2)$ and
 $b:=(b_1,b_2)$. We claim that if
 $a_1\geqslant b_1$ and
 $a_2\geqslant b_2$, then
 $a\geqslant b$. Moreover if
 $a_1>b_1$ or
 $a_2>b_2$, then we say
 $a>b$.
Let  $\Omega \subseteq \mathbb {R}$ be an interval, including
 $\Omega =\mathbb {R}$.
 $L^{P}(\Omega )\ (p\geqslant 1)$ is the Lebesgue space of the integrable functions defined on
 $\Omega$ and
 $W^{k,p}(\Omega )\ (k\geqslant 0,p\geqslant 1)$ is the Sobolev space of the
 $L^{p}$-functions
 $f(x)$ defined on the the interval
 $\Omega$, whose derivatives
 $({d^{i}}/{dx^{i}})f\ (i=0,\ldots ,k)$ also belong to
 $L^{p}(\Omega )$. Particularly, when
 $p=2$,
 $W^{k,2}(\Omega )=H^{k}(\Omega )$. Moreover,
 $L^{p}_{\omega }(\Omega )$ stands for the weighted
 $L^{p}$-space for a positive weight function with the norm defined as
 \begin{equation*} \|f\|_{L^{p}_{\omega}(\Omega)}=\left(\int_{\Omega}\omega(x)|f(x)|^{p} \textrm{d}x\right)^{{1}/{p}}, \end{equation*}
and  $W^{k,p}_{\omega }(\Omega )$ is the weighted Sobolev space with the norm given by
 \begin{equation*} \|f\|_{W^{k,p}_{\omega}(\Omega)}=\left(\sum\limits^{k}_{i=0}\int_{\Omega}\omega(x) \left|\frac{\textrm{d}^{i}}{\textrm{d}x^{i}}f(x)\right|^{p}\textrm{d}x\right)^{{1}/{p}}, \end{equation*}
 $H^{k}_{\omega }(\Omega )$ is the weighted Sobolev space with the norm given by
 \begin{equation*} \|f\|_{H^{k}_{\omega}(\Omega)}=\left(\sum\limits^{k}_{i=0}\int_{\Omega}\omega(x) \left|\frac{\textrm{d}^{i}}{\textrm{d}x^{i}}f(x)\right|^{2}\textrm{d}x\right)^{{1}/{2}}. \end{equation*}
In addition, let  $0< T\leqslant +\infty$ be a number and
 $\mathbb {B}$ be a Banach space, then
 $C^{0}([0,T],\mathbb {B})$ is the space of the
 $\mathbb {B}$-valued continuous functions on
 $[0,T]$, and
 $L^{2}([0,T],\mathbb {B})$ is the space of the
 $\mathbb {B}$-valued
 $L^{2}$-functions on
 $[0,T]$.
3. Spreading problems
In this section, by constructing different kinds of suitable super-sub solutions, we will give some new conditions on the existence of travelling wave fronts of (2.1) for any  $d>0$, which improve the conditions given in [Reference Hou and Leung7], and some sufficient conditions on the linear or nonlinear speed selection, which enlarge the conditions on the linear speed selection in [Reference Lewis, Li and Weinberger9].
3.1. New conditions on the existence of travelling wave fronts
In this subsection, we will establish some sufficient conditions on the existence of travelling wave fronts of (2.1) by the super-sub solution method. Let
 \begin{align*} F(\phi,\psi)&=\phi''-c\phi'+\phi(1-k_1-\phi+k_1\psi),\\ G(\phi,\psi)&=d\psi''-c\psi'+r(1-\psi)(k_2\phi-\psi), \end{align*}
and define
 \begin{align} \begin{split} \overline{\phi}(\xi) & = \left\{\begin{array}{@{}ll} u^{{\ast}}\textrm{e}^{\lambda_1\xi},\quad & \xi<0 ,\\ u^{{\ast}},\quad & \xi\geqslant 0, \end{array} \right. \quad\quad \underline{\phi}(\xi)= \left\{\begin{array}{@{}ll} u^{{\ast}}(\textrm{e}^{\lambda_1\xi}-q_0\textrm{e}^{\eta_0\lambda_1\xi}),\quad & \xi\leqslant\xi_0,\\ 0, \quad & \xi>\xi_0, \end{array} \right.\\ \overline{\psi}(\xi) & = \left\{\begin{array}{@{}ll} v^{{\ast}}\textrm{e}^{\lambda_1\xi},\quad & \xi<0,\\ v^{{\ast}},\quad & \xi\geqslant 0, \end{array} \right. ~~~\quad \underline{\psi}(\xi)\equiv 0,\quad\xi\in\mathbb{R}, \end{split} \end{align}
where  $\lambda _1=\lambda _1(c)$,
 $\xi _0=({\ln q_0}/{(1-\eta _0)\lambda _1})$,
 $1<\eta _0<\min \{2,({\lambda _2}/{\lambda _1})\}$ and
 $q_0$ is large enough.
Obviously,  $\overline {\phi }\geqslant \underline {\phi }$ and
 $\overline {\psi }\geqslant \underline {\psi }$ for
 $\xi \in \mathbb {R}$. In the following, we will prove
 $F(\overline {\phi },\overline {\psi }),\ G(\overline {\phi },\overline {\psi })\leqslant 0$,
 $F(\underline {\phi },\underline {\psi }),\ G(\underline {\phi },\underline {\psi })\geqslant 0$, which means
 $(\overline {\phi },\overline {\psi })$ is a super-solution of (2.2) and
 $(\underline {\phi },\underline {\psi })$ is a sub-solution of (2.2).
When  $\xi \geqslant 0$, obviously,
 $F(\overline {\phi },\overline {\psi })=0$. If
 $\xi <0$, since
 $k_2u^{\ast }=v^{\ast }$, then we have
 \begin{align*} F(\overline{\phi},\overline{\psi})&=\lambda_1^{2}u^{{\ast}}\textrm{e}^{\lambda_1\xi}-c\lambda_1 u^{{\ast}}\textrm{e}^{\lambda_1\xi}+u^{{\ast}}\textrm{e}^{\lambda_1\xi}(1-k_1-u^{{\ast}}\textrm{e}^{\lambda_1\xi} +k_1k_2u^{{\ast}}\textrm{e}^{\lambda_1\xi})\\ &=\Delta_1(\lambda_1,c)u^{{\ast}}\textrm{e}^{\lambda_1\xi}+({-}1+k_1k_2) (u^{{\ast}})^{2}\textrm{e}^{2\lambda_1\xi}\\ &=({-}1+k_1k_2)(u^{{\ast}})^{2}\textrm{e}^{2\lambda_1\xi}<0. \end{align*}
Now we prove  $G(\overline {\phi },\overline {\psi })\leqslant 0$. Similarly, when
 $\xi \geqslant 0$, obviously,
 $G(\overline {\phi },\overline {\psi })=0$. If
 $\xi <0$, also since
 $k_2u^{\ast }=v^{\ast }$, then we deduce
 \begin{align*}
G(\overline{\phi},\overline{\psi})&=d\lambda_1^{2}v^{{\ast}}\textrm{e}^{\lambda_1\xi}-c\lambda_1
v^{{\ast}}\textrm{e}^{\lambda_1\xi}+r(1-v^{{\ast}}\textrm{e}^{\lambda_1\xi})
(k_2u^{{\ast}}\textrm{e}^{\lambda_1\xi}-v^{{\ast}}\textrm{e}^{\lambda_1\xi})\\
&=(d\lambda_1^{2}-c\lambda_1)
v^{{\ast}}\textrm{e}^{\lambda_1\xi}.
\end{align*}
If  $d\in (0,2]$, for
 $c\geqslant c_0=2\sqrt {1-k_1}$, then
 $d\lambda _1^{2}-c\lambda _1\leqslant 0$, which implies
 $G(\overline {\phi },\overline {\psi })\leqslant 0$. Also if
 $d\in (2,+\infty )$, for
 $c\geqslant \frac {d}{\sqrt {d-1}}\sqrt {1-k_1}>c_0$, we still have
 $d\lambda _1^{2}-c\lambda _1\leqslant 0$, and hence
 $G(\overline {\phi },\overline {\psi })\leqslant 0$.
For  $\xi \in \mathbb {R}$,
 $G(\underline {\phi },\underline {\psi })=r(1-\underline {\psi }) (k_2\underline {\phi }-\underline {\psi })=rk_2\underline {\phi }\geqslant 0$. Finally, we show that
 $F(\underline {\phi },\underline {\psi })\geqslant 0$. When
 $\xi >\xi _0$,
 $F(\underline {\phi },\underline {\psi })=0$. On the other hand, if
 $\xi \leqslant \xi _0$, we have
 \begin{align*}
F(\underline{\phi},\underline{\psi})&=u^{{\ast}}\Delta_1(\lambda_1,c)\textrm{e}^{\lambda_1\xi}
-u^{{\ast}}q_0\Delta_1(\eta_0\lambda_1,c)\textrm{e}^{\eta_0\lambda_1\xi}\\
&\quad -(u^{{\ast}})^{2}(\textrm{e}^{\lambda_1\xi}-q_0\textrm{e}^{\eta_0\lambda_1\xi})\textrm{e}^{\lambda_1\xi}
+q_0(u^{{\ast}})^{2}\textrm{e}^{\eta_0\lambda_1\xi}(\textrm{e}^{\lambda_1\xi}
-q_0\textrm{e}^{\eta_0\lambda_1\xi})\\
&\geqslant -u^{{\ast}}\left[q_0\Delta_1(\eta_0\lambda_1,c)
+u^{{\ast}}\textrm{e}^{(2-\eta_0)\lambda_1\xi}\right]\textrm{e}^{\eta_0\lambda_1\xi}.
\end{align*}
For  $c>c_0$, taking
 $1<\eta _0<\min \{2,({\lambda _2}/{\lambda _1})\}$ and a large
 $q_0$ gives
 $F(\underline {\phi },\underline {\psi })\geqslant 0$. Thus
 $(\overline {\phi },\overline {\psi })$ is a super-solution of (2.2) and
 $(\underline {\phi },\underline {\psi })$ is a sub-solution of (2.2).
From [Reference Alhasanat and Ou1, Reference Alhasanat and Ou2, Reference Ma13] and references therein, for  $c>c_0$,
 $(\overline {\phi },\overline {\psi })$ and
 $(\underline {\phi },\underline {\psi })$ are the super-sub solutions of the corresponding integral system derived from (2.2)–(2.3), respectively. According to this integral system, the corresponding integral operator can be defined, thus an iteration sequence
 $\{(u_n,v_n)\}$ is obtained, where
 $u_0=\overline {\phi }$,
 $v_0=\overline {\psi }$, which converges to a pair of increasing functions
 $(\phi ,\psi )$ satisfying (2.2)–(2.3) with
 $\underline {\phi }\leqslant \phi \leqslant \overline {\phi }$,
 $\underline {\psi }\leqslant \psi \leqslant \overline {\psi }$. For
 $c=c_0$, the result can be obtained by Helly's Theorem and a limiting argument similar to [Reference Brown and Carr4, Reference Zhao and Wang28, Reference Zhao and Xiao29] and references therein. The uniqueness and strict monotonicity can be further proved by the sliding method in [Reference Li, Huang and Li10], and we omit the details here. Thus we establish the following result.
Theorem 3.1 If  $d\in (0,2]$ with
 $c\geqslant c_0$ or
 $d\in (2,+\infty )$ with
 $c\geqslant \frac {d}{\sqrt {d-1}}\sqrt {1-k_1}$, then there exists a unique strictly increasing solution (up to a translation) to (2.2)–(2.3).
Remark 3.2 If we define  $c(d)=\frac {d}{\sqrt {d-1}}\sqrt {1-k_1}$, then
 $c(2)=2\sqrt {1-k_1}=c_0$.
3.2. Linear speed selection
In this subsection, we further discuss the sufficient conditions on the linear speed selection, which is concluded in the following theorem.
Theorem 3.3 The minimal speed is linearly selected if one of the following conditions holds:
(C1)
$0< d\leqslant 2$;(C2)
$2< d\leqslant 2+\frac {r\hat {v}^{\ast }}{1-k_1}$ and $\frac {r}{r-(d-2)(1-k_1)}<\frac {2(1-k_1k_2)}{k_1k_2}$;(C3)
$2+\frac {r\hat {v}^{\ast }}{1-k_1}< d<2+\frac {r}{1-k_1}$ and $\frac {r}{r-(d-2)(1-k_1)}<\min $ $\left \{\frac {2d(1-k_1)}{(d-2)(1-k_1)-r\hat {v}^{\ast }},\right. \left.\frac {2(1-k_1k_2)}{k_1k_2}\right \}$,


where  $\hat {v}^{\ast }=\frac {1-k_2}{1-k_1k_2}$.
Remark 3.4 In this remark, we verify that the parameter range in cases (C2) or (C3) is not empty by giving some specific figures. First of all, since  $\hat {v}^{\ast }<1$, then
 $2+({r\hat {v}^{\ast }}/{1-k_1})<2+({r}/{1-k_1})$, which implies that in the case (C2) or (C3),
 \begin{equation*} r-(d-2)(1-k_1)>0. \end{equation*}
Choose  $k_1=k_2=\frac {1}{2}$,
 $r=1$,
 $d=\frac {8}{3}$, then
 $\hat {v}^{\ast }=\frac {2}{3}$,
 $\frac {r}{1-k_1}=2$, thus
 \begin{align*} 2< d=\frac{8}{3}<\frac{10}{3}=2+\frac{r\hat{v}^{{\ast}}}{1-k_1},\quad \frac{r}{r-(d-2)(1-k_1)}=\frac{3}{2}<6=\frac{2(1-k_1k_2)}{k_1k_2}, \end{align*}
which is the case (C2), and the minimal speed is linearly selected.
On the other hand, set  $k_1=k_2=\frac {1}{2}$,
 $r=1$,
 $d=\frac {7}{2}$, then
 $\hat {v}^{\ast }=\frac {2}{3}$,
 $\frac {r}{1-k_1}=2$, thus
 \begin{align*} &2+\frac{r\hat{v}^{{\ast}}}{1-k_1}=\frac{10}{3}< d=\frac{7}{2}<4=2+\frac{r}{1-k_1},\\ &\frac{r}{r-(d-2)(1-k_1)}=4<6=\frac{2(1-k_1k_2)}{k_1k_2}<42 =\frac{2d(1-k_1)}{(d-2)(1-k_1)-r\hat{v}^{{\ast}}}, \end{align*}
which is the case (C3), the minimal speed is also linearly selected.
Remark 3.5 In this remark, we try to rewrite the inequalities in (C2) and (C3) in a consistent form both in terms of  $d$. For (C2), by directly computing, we conclude that if
 $0< k_1k_2<\frac {2}{3}$ and
 $\frac {2}{3}< k_1<1$, then
 \begin{equation*} \frac{2(d-2)(1-k_1)(1-k_1k_2)}{2-3k_1k_2}>\frac{(d-2)(1-k_1)}{\hat{v}^{{\ast}}}, \end{equation*}
while if  $0< k_1k_2<\frac {2}{3}$ and
 $0< k_1\leqslant \frac {2}{3}$, then
 \begin{equation*} \frac{2(d-2)(1-k_1)(1-k_1k_2)}{2-3k_1k_2}\leqslant\frac{(d-2)(1-k_1)}{\hat{v}^{{\ast}}}. \end{equation*}
By recalling  $0< k_2<1$, if
 $0< k_1\leqslant \frac {2}{3}$, then
 $0< k_1k_2<\frac {2}{3}$. Thus, we can rewrite (C2) as (C2)’
 $(d,r,k_1,k_2)\in L_1\cup L_2$, where
 \begin{align*} &L_1=\left\{d>2,\ r\geqslant\frac{(d-2)(1-k_1)}{\hat{v}^{{\ast}}},\ 0< k_1\leqslant\frac{2}{3}.\right\},\\ &L_2=\left\{d>2,\ r>\frac{2(d-2)(1-k_1)(1-k_1k_2)}{2-3k_1k_2},\ 0< k_1k_2<\frac{2}{3},\ \frac{2}{3}< k_1<1.\right\}. \end{align*}
For (C3), obviously, when  $0< k_1k_2<\frac {2}{3}$, then
 \begin{equation*} \frac{2(d-2)(1-k_1)(1-k_1k_2)}{2-3k_1k_2}>(d-2)(1-k_1). \end{equation*}
Then, by directly computing, we can rewrite (C3) as
 \begin{equation*} \hbox{(C3)' }(d,r,k_1,k_2)\in \left \{d>2,\ \max \{R_1,R_2\}< r< \frac {(d-2)(1-k_1)}{\hat {v}^{\ast }},\ 0< k_1k_2<\frac {2}{3}.\right \}\end{equation*}
where
 \begin{align*}
R_1&:=\frac{2(d-2)(1-k_1)(1-k_1k_2)}{2-3k_1k_2},\\
R_2&:=
(1-k_1)\frac{-d-2+\sqrt{(d+2)^{2}+8d(d-2)\hat{v}^{{\ast}}}}{2\hat{v}^{{\ast}}}.
\end{align*}
In the following, for the convenience of statements in the proof, we will prove inequalities in (C2) and (C3).
Remark 3.6 In this remark, we will compare the results in theorems 3.1 and 3.3 with previous results. In [Reference Lewis, Li and Weinberger9], when  $0< d\leqslant 2$, then the minimal speed is linearly determined. According to theorem 3.3, when the parameters satisfy (C2) or (C3), then the minimal speed is also linearly determined. Thus, our results indeed enlarge the previously known parameter ranges that insure the linear selection in [Reference Lewis, Li and Weinberger9]. Then from theorem 2.2 in [Reference Hou and Leung7], if
 \begin{equation*} (c,d,r,k_1,k_2)\in\left\{d=1,r<1,c>2\sqrt{\frac{1-k_1}{1-k_1k_2}}\right\}, \end{equation*}
then (1.1) has a travelling wave front. From theorems 3.1 and 3.3, the results in [Reference Hou and Leung7] are improved. For example, choose  $d=2$,
 $r<1$,
 $c>2\sqrt {\frac {1-k_1}{1-k_1k_2}}$, then theorem 2.2 in [Reference Hou and Leung7] is invalid, while, from (C1) in theorem 3.3, (1.1) has a travelling wave front.
Remark 3.7 In this remark, we will compare the sufficient conditions on the linear speed selection or the nonlinear speed selection with the conclusions on travelling wave fronts connecting  $(0,1)$ and
 $(1,0)$ in the case (i). From theorem 3.3, if
 $0< d\leqslant 2$, the sufficient condition of linear speed selection depends only on
 $d$, which is simple compared with the conditions in [Reference Alhasanat and Ou2] for the travelling wave front of (1.1) connecting
 $(0,1)$ and
 $(1,0)$ in the case (i). These conclusions demonstrate that the sufficient conditions on the linear speed selection of the minimal wave speed of travelling wave fronts of (1.1) connecting different equilibria are quite different. Moreover, since
 $c_0=2\sqrt {1-k_1}$, thus the linear speed selection depends only on
 $\lambda _1$. Indeed, from the asymptotic behaviour in § 2, when
 $0< d<2+({r}/{1-k_1})$,
 $\lambda _1$ is the smallest positive root of (2.4). Therefore, when
 $0< d<2+({r}/{1-k_1})$, one can construct a suitable super-sub solutions related to
 $\textrm {e}^{\lambda _1\xi }$. Meanwhile, if
 $d>2+({r}/{1-k_1})$, then the minimal speed is nonlinearly selected, see theorem 3.13 below.
The case (C1) obviously follows from theorem 3.1. The rest will be proved by constructing some suitable super-sub solutions.
Lemma 3.8 When  $c>c_0$, the functions
 $\underline {\phi }$,
 $\underline {\psi }$ satisfy
 $F(\underline {\phi },\underline {\psi }),\ G(\underline {\phi },\underline {\psi })\geqslant 0$, where
 \begin{equation*} \underline{\phi}(\xi)= \left\{ \begin{array}{@{}ll} \textrm{e}^{\lambda_1\xi}(1-q_1\textrm{e}^{\varepsilon_1\xi}),\quad & \xi<\xi_1,\\ 0,\quad & \xi\geqslant\xi_1, \end{array} \right. \end{equation*}
 $\xi _1=\frac {1}{\varepsilon _1}\ln \frac {1}{q_1}<0$ for
 $0<\varepsilon _1<\min \{\lambda _1,\lambda _2-\lambda _1\}$ and large positive
 $q_1$, and
 $\underline {\psi }=0$.
Proof. Since  $\underline {\phi }\geqslant 0$, then obviously
 $G(\underline {\phi },\underline {\psi })=rk_2\underline {\phi }\geqslant 0$. We continue to prove
 $F(\underline {\phi },\underline {\psi })\geqslant 0$. If
 $\xi <\xi _1$, we have
 \begin{align*}
F(\underline{\phi},\underline{\psi})&=-q_1\Delta_1(\lambda_1+\varepsilon_1,c)
\textrm{e}^{(\lambda_1+\varepsilon_1)\xi}-(1-q_1\textrm{e}^{\varepsilon_1\xi})\textrm{e}^{2\lambda_1\xi}\\
&\quad +q_1(1-q_1\textrm{e}^{\varepsilon_1\xi})\textrm{e}^{(2\lambda_1+\varepsilon_1)\xi}\\
&\geqslant \left[{-}q_1\Delta_1(\lambda_1+\varepsilon_1,c)
-(1-q_1\textrm{e}^{\varepsilon_1\xi})\textrm{e}^{(\lambda_1-\varepsilon_1)\xi}\right]
\textrm{e}^{(\lambda_1+\varepsilon_1)\xi}\\ &\geqslant 0
\end{align*}
for  $c>c_0$,
 $0<\varepsilon _1<\min \{\lambda _1,\lambda _2-\lambda _1\}$ and large positive
 $q_1$. For
 $\xi \geqslant \xi _1$,
 $F(\underline {\phi },\underline {\psi })=0$.
Then we focus on the construction of the functions  $\overline {\phi }$,
 $\overline {\psi }$.
Lemma 3.9 Suppose that the case (C2) or (C3) in theorem 3.3 holds. Let  $c:=c_0+\varepsilon _2$ for
 $\varepsilon _2\geqslant 0$. If
 $\varepsilon _2>0$ is sufficiently small, then the functions
 $\overline {\phi }$,
 $\overline {\psi }$ satisfy
 $F(\overline {\phi },\overline {\psi }),\ G(\overline {\phi },\overline {\psi })\leqslant 0$, where
 \begin{align} \overline{\phi}(\xi)&=u^{{\ast}}-\frac{u^{{\ast}}}{1+q_2\textrm{e}^{\lambda_1\xi}} =\frac{q_2u^{{\ast}}\textrm{e}^{\lambda_1\xi}}{1+q_2\textrm{e}^{\lambda_1\xi}}, \end{align}
 \begin{align} \overline{\psi}(\xi)&= \left\{ \begin{array}{@{}ll} q_3k_2\overline{\phi}(\xi),\quad & \xi\leqslant\xi_2,\\ v^{{\ast}},\quad & \xi>\xi_2, \end{array} \right. \end{align}
and  $q_2$ is a positive constant,
 $q_3=({r}/{r-(d-2)(1-k_1)})+\eta _1>1$ for small
 $\eta _1>0$, and
 $\xi _2$ satisfies
 $q_3k_2\overline {\phi }(\xi _2)=v^{\ast }$.
Proof. We firstly prove  $G(\overline {\phi },\overline {\psi })\leqslant 0$. For
 $\xi >\xi _2$, by (3.2), we have
 \begin{equation*} G(\overline{\phi},\overline{\psi})=rk_2(1-v^{{\ast}}) (\overline{\phi}-u^{{\ast}})\leqslant 0. \end{equation*}
On the other hand, if  $\xi \leqslant \xi _2$, since
 $\overline {\phi }'=\lambda _1\overline {\phi }(1-\displaystyle \frac {\overline {\phi }} {u^{\ast }})$,
 $\overline {\phi }''=\lambda _1\overline {\phi } (1-\displaystyle \frac {\overline {\phi }}{u^{\ast }}) (\lambda _1-\displaystyle \frac {2\lambda _1}{u^{\ast }}\overline {\phi })$, we have
 \begin{align*}
G(\overline{\phi},\overline{\psi})&=
dk_2q_3\lambda_1\overline{\phi}\left(1-\frac{\overline{\phi}}{u^{{\ast}}}\right)
\left(\lambda_1-\frac{2\lambda_1}{u^{{\ast}}}\overline{\phi}\right) \\
&\quad -ck_2q_3\lambda_1\overline{\phi}\left(1-\frac{\overline{\phi}}{u^{{\ast}}}\right)
+rk_2(1-k_2q_3\overline{\phi})(\overline{\phi}-q_3\overline{\phi})\\
&=k_2\overline{\phi}\left\{ \left[
dq_3\left(\lambda_1^{2}-\frac{2\lambda_1^{2}}{u^{{\ast}}}\overline{\phi}\right)-cq_3\lambda_1
\right] \left(1-\frac{\overline{\phi}}{u^{{\ast}}}\right)
+r(1-q_3)(1-k_2q_3\overline{\phi}) \right\}.
\end{align*}
Let
 \begin{equation*} G_1(x)=q_3\lambda_1\left[d\left(\lambda_1-\frac{2\lambda_1}{u^{{\ast}}}x\right)-c\right] \left(1-\frac{x}{u^{{\ast}}}\right)+r(1-q_3)(1-k_2q_3x). \end{equation*}
Since  $\overline {\phi }\geqslant 0$, in order to prove
 $G(\overline {\phi },\overline {\psi })<0$ in
 $(-\infty ,\xi _2)$, it is sufficient to demonstrate
 $G_1(x)<0$ in
 $(0,({u^{\ast }}/{q_3}))$, which can be guaranteed by
 $G_1(0)$,
 $G_1(({u^{\ast }}/{q_3}))<0$ since
 $G''_1(x)=({4dq_3\lambda ^{2}_1}/{(u^{\ast })^{2}})>0$.
First, we have
 \begin{equation*} G_1(0)=q_3\lambda_1(d\lambda_1-c)+r(1-q_3)=q_3(d\lambda_1^{2}-c\lambda_1)+r(1-q_3). \end{equation*}
Since  $c=c_0+\varepsilon _2$ with sufficiently small
 $\varepsilon _2>0$, then
 $\lambda _1=\sqrt {1-k_1}+o(\varepsilon _2)$, and thus
 \begin{equation*} G_1(0)|_{\varepsilon_2=0}=q_3(d-2)(1-k_1)+r(1-q_3). \end{equation*}
From (C2) or (C3), we have  $2< d<2+({r}/{1-k_1})$ and
 $q_3=({r}/r-(d-2) (1-k_1))+\eta _1>1$, then
 \begin{equation*} G_1(0)|_{\varepsilon_2=0}=q_3\bigl[(d-2)(1-k_1)-r\bigr]+r={-}\eta_1\bigl[r-(d-2)(1-k_1)\bigr]<0, \end{equation*}
which still holds for small  $\varepsilon _2>0$.
Now we prove  $G_1(({u^{\ast }}/{q_3}))<0$ for small
 $\varepsilon _2>0$. Since
 \begin{equation*} G_1\left(\frac{u^{{\ast}}}{q_3}\right)=(q_3-1)\left(\frac{q_3-2}{q_3}d\lambda^{2}_1 -c\lambda_1-r\hat{v}^{{\ast}}\right), \end{equation*}
similarly, for  $\varepsilon _2=0$, we have
 \begin{equation*} G_1\left(\frac{u^{{\ast}}}{q_3}\right)\Big|_{\varepsilon_2=0}=\frac{q_3-1}{q_3} \Bigl\{ \bigl[ d(1-k_1)-2(1-k_1)-r\hat{v}^{{\ast}} \bigr]q_3-2d(1-k_1) \Bigr\}. \end{equation*}
If (C2) holds, then  $(d-2)(1-k_1)\leqslant r\hat {v}^{\ast }$, which implies that
 $G_1(({u^{\ast }}/{q_3}))<0$ for small positive
 $\varepsilon _2$. On the other hand, if (C3) holds, then
 $(d-2)(1-k_1)>r\hat {v}^{\ast }$. From (C3), since
 \begin{equation*} \frac{r}{r-(d-2)(1-k_1)}<\min\left\{\frac{2d(1-k_1)}{(d-2)(1-k_1)-r\hat{v}^{{\ast}}}, \frac{2(1-k_1k_2)}{k_1k_2}\right\}, \end{equation*}
then for small  $\eta _1$, we still have
 \begin{equation*} q_3=\frac{r}{r-(d-2)(1-k_1)}+\eta_1<\frac{2d(1-k_1)}{(d-2)(1-k_1)-r\hat{v}^{{\ast}}}, \end{equation*}
which implies  $G_1(({u^{\ast }}/{q_3}))<0$ for small
 $\varepsilon _2>0$. Therefore
 $G(\overline {\phi },\overline {\psi })<0$ for small
 $\varepsilon _2>0$.
Next we will prove  $F(\overline {\phi },\overline {\psi })\leqslant 0$. First we have
 \begin{align*}
F(\overline{\phi},\overline{\psi})&=\lambda_1\overline{\phi}
\left(1-\frac{\overline{\phi}}{u^{{\ast}}}\right)
\left(\lambda_1-\frac{2\lambda_1}{u^{{\ast}}}\overline{\phi}\right)
-c\lambda_1\overline{\phi}\left(1-\frac{\overline{\phi}}
{u^{{\ast}}}\right)+\overline{\phi}(1-k_1-\overline{\phi}+k_1\overline{\psi})\\
&=\overline{\phi}
\left(1-\frac{\overline{\phi}}{u^{{\ast}}}\right)\left[\Delta_1(\lambda_1,c)-
\frac{2\lambda_1^{2}}{u^{{\ast}}}\overline{\phi}
+\frac{{\overline{\phi}}/{u^{{\ast}}}}{1-({\overline{\phi}}/{u^{{\ast}})}}(1-k_1)\right.\\
&\quad +\left.\frac{1}{1-({\overline{\phi}}/{u^{{\ast}})}}
(-\overline{\phi}+k_1\overline{\psi})\right]\\
&=\overline{\phi}
\left(1-\frac{\overline{\phi}}{u^{{\ast}}}\right)\left\{
\frac{\overline{\phi}}{u^{{\ast}}}\left[{-}2\lambda_1^{2}+\frac{k_1}
{({\overline{\phi}}/{u^{{\ast}})}(1-({\overline{\phi}}/{u^{{\ast}}}))}
\left(\overline{\psi}+\frac{1-k_1-u^{{\ast}}}{k_1u^{{\ast}}}\overline{\phi}\right)
\right]\right\}. \end{align*}
In order to prove  $F(\overline {\phi },\overline {\psi })\leqslant 0$, it is sufficient to prove
 \begin{equation} -2\lambda_1^{2}+k_1J(\xi)<0, \end{equation}
where
 \[ J(\xi)=\frac{1} {({\overline{\phi}}/{u^{{\ast}})}(1-({\overline{\phi}}/{u^{{\ast}})})} \left(\overline{\psi}+\frac{1-k_1-u^{{\ast}}}{k_1u^{{\ast}}}\overline{\phi}\right). \]
Now we estimate  $J(\xi )$. By the definitions of
 $u^{\ast }$,
 $v^{\ast }$ and (3.3), we have
 \begin{align*} J(\xi)=(u^{{\ast}})^{2}\frac{\overline{\psi}-k_2\overline{\phi}} {\overline{\phi}(u^{{\ast}}-\overline{\phi})}&= \left\{ \begin{array}{@{}ll} (u^{{\ast}})^{2}\dfrac{k_2q_3\overline{\phi}-k_2\overline{\phi}} {\overline{\phi}(u^{{\ast}}-\overline{\phi})}, \quad & \xi\leqslant\xi_2,\\ (u^{{\ast}})^{2}\dfrac{v^{{\ast}}-k_2\overline{\phi}} {\overline{\phi}(u^{{\ast}}-\overline{\phi})},\quad & \xi>\xi_2, \end{array} \right.\\ &= \left\{ \begin{array}{@{}ll} k_2(u^{{\ast}})^{2}\dfrac{q_3-1} {u^{{\ast}}-\overline{\phi}}, \quad & \xi\leqslant\xi_2,\\ k_2(u^{{\ast}})^{2}\dfrac{1} {\overline{\phi}},\quad & \xi>\xi_2. \end{array} \right. \end{align*}
For  $\xi \leqslant \xi _2$, also from (3.3), we have
 $\overline {\phi }\leqslant ({v^{\ast }}/{k_2q_3})=({u^{\ast }}/{q_3})$. Thus
 $u^{\ast }-\overline {\phi }\geqslant u^{\ast }-({u^{\ast }}/{q_3})=({q_3-1}/{q_3}u^{\ast })$. Then
 $({1}/{u^{\ast }-\overline {\phi }})\leqslant ({q_3}/{(q_3-1)u^{\ast }})$ due to
 $q_3>1$. Hence
 \begin{equation} J(\xi)\leqslant k_2(u^{{\ast}})^{2}\frac{q_3(q_3-1)}{(q_3-1)u^{{\ast}}}=k_2q_3u^{{\ast}}. \end{equation}
For  $\xi >\xi _2$,
 $\overline {\phi }\geqslant ({u^{\ast }}/{q_3})$, thus
 \begin{equation} J(\xi)\leqslant k_2(u^{{\ast}})^{2}\frac{1}{\overline{\phi}}\leqslant k_2q_3u^{{\ast}}. \end{equation}
From (3.5)–(3.6), we conclude that  $J(\xi )\leqslant k_2q_3u^{\ast }$ on
 $\mathbb {R}$. Moreover, from (C2) or (C3) in theorem 3.3,
 $({r}/{r-(d-2)(1-k_1)})<({2(1-k_1k_2)}/{k_1k_2})$, thus for small
 $\eta _1$,
 \begin{equation*} q_3<\frac{2(1-k_1k_2)}{k_1k_2}. \end{equation*}
Therefore we have
 \begin{equation*} -2(1-k_1)+k_1k_2q_3u^{{\ast}}<0, \end{equation*}
which insure (3.4) holds for small positive  $\varepsilon _2$. Therefore
 $F(\overline {\phi },\overline {\psi })\leqslant 0$ for small
 $\varepsilon _2>0$.
From lemmas 3.8–3.9, obviously,  $\overline {\psi }(\xi )\geqslant \underline {\psi }(\xi )$, for
 $\xi \in \mathbb {R}$, and
 $\overline {\phi }(\xi )\geqslant \underline {\phi }(\xi )$, for
 $\xi \geqslant \xi _1$. While for
 $\xi <\xi _1$, we have
 \begin{equation*} \overline{\phi}(\xi)-\underline{\phi}(\xi)\geqslant \left(\frac{q_2u^{{\ast}}}{1+q_2\textrm{e}^{\lambda_1\xi}}-1\right)\textrm{e}^{\lambda_1\xi}. \end{equation*}
If  $q_2u^{\ast }-1>0$ and
 $\varepsilon _1$ is small enough, then
 $\overline {\phi }(\xi )\geqslant \underline {\phi }(\xi )$ on
 $(-\infty ,\xi _1)$.
All in all,  $(\underline {\phi },\underline {\psi })$ is a sub-solution of (2.2), and
 $(\overline {\phi },\overline {\psi })$ is a super-solution of (2.2), when
 $c$ is sufficiently close to
 $c_0$. By repeating the process given in the end of § 3.1, one can finish the proof of theorem 3.3, which implies that
 $c_{\min }=c_0$, and there exists a unique strictly increasing solution (up to a translation) to (2.2)–(2.3) when
 $c$ is sufficiently close to
 $c_0$. Moreover, since there is no other equilibria in
 $(0,u^{\ast })\times (0,v^{\ast })$ and (2.2) is cooperative, therefore (2.2)–(2.3) have an increasing solution if and only if
 $c\geqslant c_0$ from [Reference Li, Weinberger and Lewis11, Reference Volpert, Volpert and Volpert22]. Hence we finally arrive at the following conclusion.

3.3. Nonlinear speed selection
In this subsection, we are going to discuss sufficient conditions on the nonlinear speed selection. Inspired by the ideas in [Reference Alhasanat and Ou1–Reference Alhasanat and Ou3, Reference Ma, Chen, Yue and Han14, Reference Yue, Han, Tao and Ma27], in order to investigate the nonlinear speed selection by the super-sub solution method, we need to construct a pair of sub-solution  $(\underline {\phi },\underline {\psi })$, which behaves like
 $\textrm {e}^{\lambda _2\xi }$ as
 $\xi \rightarrow -\infty$. The following lemma confirms this claim.
Lemma 3.11 For some  $\tilde {c}>c_0$, assume that system (2.1) has a pair of non-negative sub-solution
 $(\underline {\phi }(\tilde {\xi }),\underline {\psi }(\tilde {\xi }))$, where
 $\tilde {\xi }=x+\tilde {c}t$. Moreover, if
 $\underline {\phi }(\tilde {\xi })$,
 $\underline {\psi }(\tilde {\xi })$ are increasing and
 $\underline {\phi }(\tilde {\xi })$,
 $\underline {\psi }(\tilde {\xi })$ satisfies
 \begin{align*} \limsup\limits_{\tilde{\xi}\rightarrow+\infty}\underline{\phi}(\tilde{\xi})< u^{{\ast}},\quad \limsup\limits_{\tilde{\xi}\rightarrow+\infty}\underline{\psi}(\tilde{\xi})< v^{{\ast}},\quad \lim\limits_{\tilde{\xi}\rightarrow-\infty}\frac{\underline{\phi}(\tilde{\xi})} {\textrm{e}^{\lambda_2\tilde{\xi}}}=K_1,\quad \lim\limits_{\tilde{\xi}\rightarrow-\infty}\frac{\underline{\psi}(\tilde{\xi})} {\textrm{e}^{\lambda_2\tilde{\xi}}}=K_2, \end{align*}
where  $K_1$ and
 $K_2$ are some positive constants, then system (2.2) has no travelling wave fronts for
 $c\in [c_0,\tilde {c})$.
Proof. For  $c\in [c_0,\tilde {c})$, suppose that there is a travelling wave front
 $(\phi (x+ct),\psi (x+ct))$ to (2.1) with the initial conditions
 \begin{equation*} u(x,0)=\phi(x),\qquad v(x,0)=\psi(x), \end{equation*}
which also are increasing solutions to (2.2) with (2.3). By recalling the asymptotic behaviour in § 2 and (2.3), one can further assume that  $\underline {\phi }(x)\leqslant \phi (x)$ and
 $\underline {\psi }(x)\leqslant \psi (x)$ in
 $\mathbb {R}$, by shifting if necessary. Then, by the comparison theorem of parabolic systems with initial values, for
 $(x,t)\in \mathbb {R}\times \mathbb {R^{+}}$, we have
 \begin{equation} \underline{\phi}(x+\tilde{c}t)\leqslant\phi(x+ct),\qquad \underline{\psi}(x+\tilde{c}t)\leqslant\psi(x+ct). \end{equation}
Fix  $\tilde {\xi }_1=x+\tilde {c}t$ such that
 $\underline {\phi }(\tilde {\xi }_1)>0$. Furthermore, as
 $t\rightarrow \infty$,
 $\phi (x+ct)=\phi (\tilde {\xi }_1+(c-\tilde {c})t)$ converges to
 $0$. Thus, by (3.7), we have
 \begin{equation*} 0\leq \underline{\phi}(\tilde{\xi}_1)\leqslant\phi(x+ct)=\phi(\tilde{\xi}_1+(c-\tilde{c})t)\to 0, \ \ \mbox{as}\ \ t\rightarrow\infty, \end{equation*}
which implies  $\underline {\phi }(\tilde {\xi }_1)=0$, and this is a contradiction.
Now we introduce the following functions
 \begin{equation} \underline{\phi}(\xi)= \left\{ \begin{array}{@{}ll} \textrm{e}^{\lambda_2\xi}+\textrm{e}^{\eta_2\lambda_2\xi},\quad & \xi<\xi_3,\\ \varepsilon_3,\quad & \xi\geqslant\xi_3, \end{array} \right.\quad \underline{\psi}(\xi)= \left\{ \begin{array}{@{}ll} q_4\textrm{e}^{\lambda_2\xi},\quad & \xi\leqslant 0,\\ q_4,\quad & \xi>0, \end{array} \right. \end{equation}
where  $1<\eta _2<2$,
 $0<\varepsilon _3<1-k_1$ is small enough such that
 \begin{equation*} \Delta_1(\eta_2\lambda_2,c)-\textrm{e}^{(2-\eta_2)\xi}-2\textrm{e}^{\lambda\xi}-\textrm{e}^{\eta_2\lambda_2\xi}>0 \end{equation*}
on  $(-\infty ,\xi _3]$, and
 $q_4\leqslant k_2\varepsilon _3$. We explain the rationality of
 $\varepsilon _3$. Since
 $\underline {\phi }'\geqslant 0$ on
 $\mathbb {R}$, then
 $\xi _3$ in (3.8) is unique. Obviously, as
 $\varepsilon _3$ decreases to
 $0$,
 $\xi _3$ converges to
 $-\infty$. Thus, for
 $\xi \in (-\infty ,\xi _3]$, we can take
 $\varepsilon _3$ that is small enough such that
 \begin{equation*} \Delta_1(\eta_2\lambda_2,c)-\textrm{e}^{(2-\eta_2)\xi}-2\textrm{e}^{\lambda\xi}-\textrm{e}^{\eta_2\lambda_2\xi}>0, \end{equation*}
by noting  $\eta _2\lambda _2>\lambda _2$ and
 $\Delta _1(\eta _2\lambda _2,c)>\Delta _1(\lambda _2,c)=0$. Directly computing gives
 \begin{equation*} \underline{\phi}',\ \underline{\psi}'\geqslant 0,\qquad\lim\limits_{\xi\rightarrow-\infty} \frac{\underline{\phi}(\xi)}{\textrm{e}^{\lambda_2\xi}}=1,\quad \lim\limits_{\xi\rightarrow-\infty} \frac{\underline{\psi}(\xi)}{\textrm{e}^{\lambda_2\xi}}=q_4, \end{equation*}
and
 \begin{equation*} \lim\limits_{\xi\rightarrow+\infty} \underline{\phi}(\xi)=\varepsilon_3<1-k_1< u^{{\ast}},\qquad \lim\limits_{\xi\rightarrow+\infty}\underline{\psi}(\xi)=q_4< k_2\varepsilon_3< v^{{\ast}}. \end{equation*}
Then in order to prove nonlinear speed selection, we only need to consider these functions are the subsolutions to (2.1) with some  $c>c_0$. Since
 $({\partial }/{\partial t})\underline {\phi }(\xi )=c\underline {\phi }'(\xi )$ and
 $({\partial }/{\partial x})\underline {\phi }(\xi )=\underline {\phi }'(\xi )$, then a subsolution of (2.1) is equivalent to a subsolution of (2.2). Thus we only need to consider
 $F(\underline {\phi },\underline {\psi }),\ G(\underline {\phi },\underline {\psi })\geqslant 0$ with some
 $c>c_0$, which is completed in the following lemma.
Lemma 3.12 Suppose that  $d>2+({r}/{1-k_1})$. Let
 $c:=c_0+\varepsilon _4$. If
 $\varepsilon _4>0$ is sufficiently small such that
 $c_0+\varepsilon _4<\hat {c}$, then the functions given in (3.8) satisfy
 $F(\underline {\phi },\underline {\psi }),\ G(\underline {\phi },\underline {\psi })\geqslant 0$.
Proof. For  $\xi \leqslant \xi _3$, by recalling the choice of
 $\varepsilon _3$,
 \begin{align*}
F(\underline{\phi},\underline{\psi})&=\Delta_1(\lambda_2,c)\textrm{e}^{\lambda_2\xi}
+\Delta_1(\eta_2\lambda_2,c)\textrm{e}^{\eta_2\lambda_2\xi} \\
&\quad -(\textrm{e}^{\lambda_2\xi}+\textrm{e}^{\eta_2\lambda_2\xi})^{2}
+k_1(\textrm{e}^{\lambda_2\xi}+\textrm{e}^{\eta_2\lambda_2\xi})\underline{\psi}\\
&\geqslant
[\Delta_1(\eta_2\lambda_2,c)-\textrm{e}^{(2-\eta_2)\lambda_2\xi}
-2\textrm{e}^{\lambda\xi}-\textrm{e}^{\eta_2\lambda_2\xi}]\textrm{e}^{\eta_2\lambda_2\xi}\\
&\geqslant 0. \end{align*}
For  $\xi >\xi _3$, since
 $\xi <1-k_1$, then
 $F(\underline {\phi },\underline {\psi })=\varepsilon _3 (1-k_1-\varepsilon _3+k_1\underline {\psi })\geqslant 0$.
We continue to prove  $G(\underline {\phi },\underline {\psi })\geqslant 0$. Since
 $d>2+({r}/{1-k_1})$ and
 $c_0< c_0+\varepsilon _4<\hat {c}$, then from
 $\mathbf {case}$
 $\mathbf {3}$ in the asymptotic behaviour, we have
 $\lambda _3<\lambda _2$, which implies
 $\Delta _2(\lambda _2,c)>0$. Combining this fact and
 $0< q_4< v^{\ast }<1$ gives
 \begin{equation*} G(\underline{\phi},\underline{\psi})=q_4\Delta_2(\lambda_2,c)\textrm{e}^{\lambda_2\xi} +rk_2\underline{\phi}(1-q_4\textrm{e}^{\lambda_2\xi})+rq^{2}_4\textrm{e}^{2\lambda_2\xi}\geqslant 0. \end{equation*}
For  $\xi >0$, by recalling
 $0< q_4< k_2\varepsilon _3<1$, we have
 \begin{equation*} G(\underline{\phi},\underline{\psi})=r(1-q_4)(k_2\varepsilon_3-q_4)\geqslant 0. \end{equation*}
Hence, from lemmas 3.11–3.12, we have the following nonlinear speed selection theorem.
Theorem 3.13 The minimal speed is nonlinearly selected if
(C4)  $d>2+({r}/{1-k_1})$.


4. Nonlinear stability of travelling wave fronts
In this section, we will discuss the stability of travelling wave fronts of (2.1). We introduce the following initial data
 \begin{equation} \left\{ \begin{array}{@{}ll} u(x,0)=u_0(x),\\ v(x,0)=v_0(x), \end{array} \right. \end{equation}
where  $0\leqslant u_0\leqslant u^{\ast }$,
 $0\leqslant v_0\leqslant v^{\ast }$ and
 \begin{equation} u_0(x)-\phi(x),\ \ v_0(x)-\psi(x)\in H^{1}_{\omega}(\mathbb{R}), \end{equation}
 $\omega$ is a weighted function precise below and
 $(\phi ,\psi )$ is the strictly increasing solution to (2.2)–(2.3). Similar to [Reference Mei, Lin, Lin and So15], we have
 \begin{equation*} u(x,\cdot)-\phi(x+c\cdot),\quad v(x,\cdot)-\psi(x+c\cdot)\in C([0,\infty),H^{1}_{\omega}(\mathbb{R})), \end{equation*}
where  $(u(x,t),v(x,t))$ represents the solution to (2.1) with (4.1). From the comparison theorem, we know that
 \begin{equation*} 0\leqslant u(x,t)\leqslant u^{{\ast}},\qquad 0\leqslant v(x,t)\leqslant v^{{\ast}}. \end{equation*}
In the following, we will prove  $u(x,t)-\phi (x+ct)$,
 $v(x,t)-\psi (x+ct)$ are exponentially converging to zero in supremum norm as
 $t\to \infty$. In order to do it, let
 $(\tilde {u}^{+}(x,t),\tilde {v}^{+}(x,t))$,
 $(\tilde {u}^{-}(x,t),\tilde {v}^{-}(x,t))$ be the solutions to (2.1) with initial conditions
 $(\tilde {u}^{\pm }_0(x),\tilde {v}^{\pm }_0(x))$, respectively, where
 \begin{align*} \tilde{u}^{+}_0(x)=\max\{u_0(x),\phi(x)\},\qquad \tilde{v}^{+}_0(x)=\max\{v_0(x),\psi(x)\},\\ \tilde{u}^{-}_0(x)=\min\{u_0(x),\phi(x)\},\qquad \tilde{v}^{-}_0(x)=\min\{v_0(x),\psi(x)\}. \end{align*}
Then from the comparison theorem we also have
 \begin{align*} &0\leqslant\tilde{u}^{-}(x,t)\leqslant u(x,t)\leqslant\tilde{u}^{+}(x,t)\leqslant u^{{\ast}},\\ &0\leqslant\tilde{v}^{-}(x,t)\leqslant v(x,t)\leqslant\tilde{v}^{+}(x,t)\leqslant v^{{\ast}},\\ &0\leqslant\tilde{u}^{-}(x,t)\leqslant\phi(x+ct)\leqslant\tilde{u}^{+}(x,t)\leqslant u^{{\ast}},\\ &0\leqslant\tilde{v}^{-}(x,t)\leqslant\psi(x+ct)\leqslant\tilde{v}^{+}(x,t)\leqslant v^{{\ast}}. \end{align*}
Furthermore, since  $\tilde {u}^{\pm }_0(x)$ and
 $\tilde {v}^{\pm }_0(x)$ are lacking smoothness, then one can choose smooth functions
 $u^{\pm }_0(x)$,
 $v^{\pm }_0(x)$ such that
 \begin{equation} \begin{array}{ll} 0\leqslant u^{-}_0(x)\leqslant\tilde{u}^{-}_0(x)\leqslant\tilde{u}^{+}_0(x)\leqslant u^{+}_0(x)\leqslant u^{{\ast}},\\ 0\leqslant v^{-}_0(x)\leqslant\tilde{v}^{-}_0(x)\leqslant\tilde{v}^{+}_0(x)\leqslant v^{+}_0(x)\leqslant v^{{\ast}}. \end{array} \end{equation}
By (4.3), the solutions  $(u^{\pm }(x,t),v^{\pm }(x,t))$ to (2.1) with initial conditions
 $(u^{\pm }_0(x),v^{\pm }_0(x))$, satisfy
 \begin{align*} &0\leqslant u^{-}(x,t)\leqslant u(x,t)\leqslant u^{+}(x,t)\leqslant u^{{\ast}},\\ &0\leqslant v^{-}(x,t)\leqslant v(x,t)\leqslant v^{+}(x,t)\leqslant v^{{\ast}},\\ &0\leqslant u^{-}(x,t)\leqslant\phi(x+ct)\leqslant u^{+}(x,t)\leqslant u^{{\ast}},\\ &0\leqslant v^{-}(x,t)\leqslant\psi(x+ct)\leqslant v^{+}(x,t)\leqslant v^{{\ast}}. \end{align*}
It is sufficient to estimate  $u^{+}(x,t)-\phi (x+ct)$ and
 $u^{-}(x,t)-\phi (x+ct)$ to obtain the estimate of
 $u(x,t)-\phi (x+ct)$, since the last one can be sandwiched between the former ones. So is the estimate of
 $v(x,t)-\psi (x+ct)$. Moreover, the proofs of estimating
 $u^{+}(x,t)-\phi (x+ct)$,
 $v^{+}(x,t)-\psi (x+ct)$ and
 $u^{-}(x,t)-\phi (x+ct)$,
 $v^{-}(x,t)-\psi (x+ct)$ are similar, thus we only consider the former two ones.
Let
 \begin{equation*} U(\xi,t)=u^{+}(x,t)-\phi(\xi),\qquad V(\xi,t)=v^{+}(x,t)-\psi(\xi), \end{equation*}
which are non-negative and satisfy
 \begin{equation} \left\{\begin{array}{@{}ll} U_t+cU_{\xi}-U_{\xi\xi}-(1-k_1)U=f_1(U+\phi,V+\psi)-f_1(\phi,\psi),\\ V_t+cV_{\xi}-dV_{\xi\xi}+rV=g_1(U+\phi,V+\psi)-g_1(\phi,\psi), \end{array} \right. \end{equation}
where  $f_1(u,v)=-u^{2}+k_1uv$ and
 $g_1(u,v)=rk_2u-rk_2uv+rv^{2}$. Then (4.4) is equivalent to
 \begin{equation} \left\{\begin{array}{@{}ll} U_t+cU_{\xi}-U_{\xi\xi}-(1-k_1)U-f_{1_{u}}U-f_{1_{v}}V =\widetilde{F}(\xi,t),\\ V_t+cV_{\xi}-dV_{\xi\xi}+rV-g_{1_{u}}U-g_{1_{v}}V =\widetilde{G}(\xi,t), \end{array} \right. \end{equation}
where  $f_{1_{u}}=({\partial f_1}/{\partial u})(\phi ,\psi )$,
 $f_{1_{v}}=({\partial f_1}/{\partial v})(\phi ,\psi )$,
 $g_{1_{u}}=({\partial g_1}/{\partial u})(\phi ,\psi )$,
 $g_{1_{v}}=({\partial g_1}/{\partial v})(\phi ,\psi )$ for short, and
 \begin{align*} \widetilde{F}(\xi,t)=f_1(U+\phi,V+\psi)-f_1(\phi,\psi)-f_{1_{u}}(\phi,\psi)U -f_{1_{v}}(\phi,\psi)V,\\ \widetilde{G}(\xi,t)=g_1(U+\phi,V+\psi)-g_1(\phi,\psi)-g_{1_{u}}(\phi,\psi)U -g_{1_{v}}(\phi,\psi)V. \end{align*}
Moreover, since  $f_{1_{uu}}=-2$,
 $f_{1_{uv}}=k_1$,
 $f_{1_{vv}}=0$,
 $g_{1_{uu}}=0$,
 $g_{1_{uv}}=-rk_2$ and
 $g_{1_{vv}}=2r$, then
 \begin{equation*} \widetilde{F}(\xi,t)=({-}U+k_1V)U,\qquad \widetilde{G}(\xi,t)=({-}rk_2U+rV)V. \end{equation*}
Now we choose a weight function as follows:
 \begin{equation} \omega(\xi)= \left\{ \begin{array}{@{}ll} \textrm{e}^{{-}2\tilde{\lambda}(\xi-\xi_4)},\quad & \xi\leqslant\xi_4,\\ 1,\quad & \xi\geqslant\xi_4, \end{array} \right. \end{equation}
where  $\xi _4$ and
 $\tilde {\lambda }>0$ are determined later. If we had proved
 $\|U\|_{H^{1}_{\omega }}\leqslant M\textrm {e}^{-\mu t}$, where
 $\mu >0$ and
 $M$ represents a general positive constant here and in the following, then by noting
 $\omega \geqslant 1$ we conclude
 \begin{equation*} \|U\|_{H^{1}}\leqslant\|U\|_{H^{1}_{\omega}}\leqslant M\textrm{e}^{-\mu t}. \end{equation*}
By the imbedding  $H^{1}(\mathbb {R})\subset C(\mathbb {R})$, we further deduce
 \begin{equation*} \sup\limits_{\mathbb{R}}|U|\leqslant M\textrm{e}^{-\mu t}, \end{equation*}
which gives the desired result. Thus we need to estimate  $U$,
 $V$,
 $U_{\xi }$ and
 $V_{\xi }$ in the space
 $L^{2}_{\omega }$.
Multiplying the first equation of (4.5) by  $\textrm {e}^{2\mu t}\omega (\xi )U$ and the second equation of (4.5) by
 $\textrm {e}^{2\mu t}\omega (\xi )V$ yields that
 \begin{align} \left\{\begin{array}{@{}ll} \textrm{e}^{2\mu t}\omega UU_t+c\textrm{e}^{2\mu t}\omega UU_{\xi}-\textrm{e}^{2\mu t}\omega UU_{\xi\xi}-A^{1}_{11}\textrm{e}^{2\mu t}\omega U^{2}-f_{1_{v}}\textrm{e}^{2\mu t}\omega UV =\widetilde{F}\textrm{e}^{2\mu t}\omega U,\\ \textrm{e}^{2\mu t}\omega VV_t+c\textrm{e}^{2\mu t}\omega VV_{\xi}-d\textrm{e}^{2\mu t}\omega VV_{\xi\xi}+A^{1}_{21}\textrm{e}^{2\mu t}\omega V^{2}-g_{1_{u}}\textrm{e}^{2\mu t}\omega UV =\widetilde{G}\textrm{e}^{2\mu t}\omega V, \end{array} \right. \end{align}
where
 \begin{align*}
\widetilde{F}&=\tilde{F}(\xi,t),\quad
\widetilde{G}=\tilde{G}(\xi,t),\quad
A^{1}_{11}:=A^{1}_{11}(\xi,t)=1-k_1+f_{1_{u}},\\
A^{1}_{21}&:=A^{1}_{21}(\xi,t)=r-g_{1_{v}}.
\end{align*}
Since
 \begin{align*}
\textrm{e}^{2\mu t}\omega
UU_t&=\frac{1}{2}(\textrm{e}^{2\mu t}\omega U^{2})_t-\mu
\textrm{e}^{2\mu t}\omega U^{2},\\
\textrm{e}^{2\mu
t}\omega UU_{\xi}&=\frac{1}{2}(\textrm{e}^{2\mu t}\omega
U^{2})_{\xi}-\frac{1}{2} \textrm{e}^{2\mu t}\omega'U^{2},\\
\textrm{e}^{2\mu t}\omega UU_{\xi\xi}&=(\textrm{e}^{2\mu
t}\omega UU_{\xi})_{\xi}-\textrm{e}^{2\mu t}\omega
U^{2}_{\xi}-\textrm{e}^{2\mu t}\omega'UU_{\xi},
\end{align*}
then (4.7) becomes
 \begin{align}
\left\{\begin{array}{@{}ll} \dfrac{1}{2}(\textrm{e}^{2\mu
t}\omega U^{2})_t+(A^{1}_{12})_{\xi}+(A^{1}_{13}\omega
U^{2}+\omega U^{2}_{\xi}+\omega'UU_{\xi}\\
\quad -f_{1_{v}}\omega
UV)\textrm{e}^{2\mu t}=\widetilde{F}\textrm{e}^{2\mu
t}\omega U,\\ \dfrac{1}{2}(\textrm{e}^{2\mu
t}\omega V^{2})_t+(A^{1}_{22})_{\xi}+(A^{1}_{23} \omega
V^{2}+d\omega V^{2}_{\xi}+d\omega'VV_{\xi}\\
\quad -g_{1_{u}}\omega
UV)\textrm{e}^{2\mu t}=\widetilde{G}\textrm{e}^{2\mu
t}\omega V, \end{array} \right.
\end{align}
where
 \begin{align*} &A^{1}_{12}:=A^{1}_{12}(\xi,t)=\frac{c}{2}\textrm{e}^{2\mu t}\omega U^{2}-\textrm{e}^{2\mu t}\omega UU_{\xi},\\ &A^{1}_{22}:=A^{1}_{22}(\xi,t)=\frac{c}{2}\textrm{e}^{2\mu t}\omega V^{2}-d\textrm{e}^{2\mu t}\omega VV_{\xi},\\ &A^{1}_{13}:=A^{1}_{13}(\xi,t)={-}\mu-\frac{c}{2}\frac{\omega'}{\omega}-1+k_1-f_{1_{u}}, \\ &A^{1}_{23}:=A^{1}_{23}(\xi,t)={-}\mu-\frac{c}{2}\frac{\omega'}{\omega}+r-g_{1_{v}}. \end{align*}
By remarking  $|xy|\leqslant x^{2}+\frac {1}{4}y^{2}$, we have
 \begin{align*} &|\omega'UU_{\xi}|\leqslant\omega U^{2}_{\xi}+\frac{1}{4}\omega\left(\frac{\omega'}{\omega}\right)^{2}U^{2},\quad f_{1_{v}}UV\leqslant k_1\phi U^{2}+\frac{1}{4}k_1\phi V^{2},\\ &|\omega'VV_{\xi}|\leqslant\omega V^{2}_{\xi}+\frac{1}{4}\omega\left(\frac{\omega'}{\omega}\right)^{2}V^{2},\quad g_{1_{u}}UV\leqslant \frac{rk_2}{4}(1-\psi)U^{2}+rk_2(1-\psi)V^{2}. \end{align*}
Thus, from (4.8), one can further obtain that
 \begin{equation}
\left\{\begin{array}{@{}ll} \dfrac{1}{2}(\textrm{e}^{2\mu
t}\omega
U^{2})_t+(A^{1}_{12})_{\xi}-A^{1}_{14}\textrm{e}^{2\mu
t}\omega V^{2}+A^{1}_{15}\textrm{e}^{2\mu t}\omega
U^{2}\leqslant A^{1}_{16}\textrm{e}^{2\mu t}\omega U^{2},\\
\dfrac{1}{2}(\textrm{e}^{2\mu t}\omega
V^{2})_t+(A^{1}_{22})_{\xi}-A^{1}_{24}\textrm{e}^{2\mu
t}\omega U^{2}+A^{1}_{25}\textrm{e}^{2\mu t}\omega
V^{2}\leqslant A^{1}_{26}\textrm{e}^{2\mu t}\omega V^{2},
\end{array} \right.
\end{equation}
where
 \begin{align*} &A^{1}_{14}:=A^{1}_{14}(\xi,t)=\frac{1}{4}k_1\phi,\qquad A^{1}_{24}:=A^{1}_{24}(\xi,t)=\frac{rk_2}{4}(1-\psi),\\ &A^{1}_{15}:=A^{1}_{15}(\xi,t)={-}\mu-\frac{c}{2}\frac{\omega'}{\omega} -\frac{1}{4}\left(\frac{\omega'}{\omega}\right)^{2} -1+k_1+2\phi-k_1\psi-k_1\phi,\\ &A^{1}_{25}:=A^{1}_{25}(\xi,t)={-}\mu-\frac{c}{2}\frac{\omega'}{\omega} -\frac{d}{4}\left(\frac{\omega'}{\omega}\right)^{2} +r+rk_2\phi-2r\psi-rk_2(1-\psi),\\ &A^{1}_{16}:=A^{1}_{16}(\xi,t)={-}U+k_1V,\quad A^{1}_{26}:=A^{1}_{26}(\xi,t)={-}rk_2U+rV. \end{align*}
Integrating (4.9) over  $[0,t]\times \mathbb {R}$ gives
 \begin{align}
\left\{\begin{array}{@{}ll}
\dfrac{1}{2}\|U\|^{2}_{L^{2}_{\omega}}\textrm{e}^{2\mu
t}-\displaystyle\int^{t}_0\displaystyle\int_{\mathbb{R}}(A^{1}_{14}\omega
V^{2}-A^{1}_{15}\omega U^{2}\\
\quad +A^{1}_{16}\omega
U^{2})\textrm{e}^{2\mu s}\textrm{d}\xi \textrm{d}s
\leqslant\dfrac{1}{2}\|U(0)\|^{2}_{L^{2}_{\omega}},\\
\dfrac{1}{2}\|V\|^{2}_{L^{2}_{\omega}}\textrm{e}^{2\mu
t}-\displaystyle\int^{t}_0\displaystyle\int_{\mathbb{R}}(A^{1}_{24}\omega
U^{2}-A^{1}_{25}\omega V^{2}\\
\quad +A^{1}_{26}\omega
V^{2})\textrm{e}^{2\mu s}\textrm{d}\xi \textrm{d}s
\leqslant\dfrac{1}{2}\|V(0)\|^{2}_{L^{2}_{\omega}}.
\end{array} \right.
\end{align}
Adding the two inequalities of (4.10) yields that
 \begin{align} &\frac{1}{2}\|U\|^{2}_{L^{2}_{\omega}}\textrm{e}^{2\mu t}+\frac{1}{2}\|V\|^{2}_{L^{2}_{\omega}}\textrm{e}^{2\mu t}+\int^{t}_0\int_{\mathbb{R}}B_1(\xi,s) \textrm{e}^{2\mu s}\omega U^{2}\textrm{d}\xi \textrm{d}s\notag\\ &\quad +\int^{t}_0\int_{\mathbb{R}}B_2(\xi,s) \textrm{e}^{2\mu s}\omega V^{2}\textrm{d}\xi \textrm{d}s\nonumber\\ &\leqslant\frac{1}{2}\|U(0)\|^{2}_{L^{2}_{\omega}}+\frac{1}{2}\|V(0)\|^{2}_{L^{2}_{\omega}}, \end{align}
where
 \begin{align*} &B_1(\xi,t)={-}\mu-\frac{c}{2}\frac{\omega'}{\omega} -\frac{1}{4}\left(\frac{\omega'}{\omega}\right)^{2} -1+k_1+2\phi-k_1\psi-k_1\phi-\frac{rk_2}{4}(1-\psi)-k_1V,\\ &B_2(\xi,t)={-}\mu-\frac{c}{2}\frac{\omega'}{\omega} -\frac{d}{4}\left(\frac{\omega'}{\omega}\right)^{2} +r+rk_2\phi-2r\psi-rk_2(1-\psi)-\frac{k_1}{4}\phi-rV. \end{align*}
By recalling  $\phi \leqslant u^{+}\leqslant u^{\ast }$,
 $\psi \leqslant v^{+}\leqslant v^{\ast }$,
 $U=u^{+}-\phi$,
 $V=v^{+}-\psi$ and (2.3), then
 \begin{align*} 0\leqslant\lim\limits_{\xi\rightarrow+\infty}U(\xi,t) =\lim\limits_{\xi\rightarrow+\infty}(u^{+}(\xi-ct,t)-\phi(\xi)) \leqslant\lim\limits_{\xi\rightarrow+\infty}(u^{{\ast}}-\phi)=0,\\ 0\leqslant\lim\limits_{\xi\rightarrow+\infty}V(\xi,t) =\lim\limits_{\xi\rightarrow+\infty}(v^{+}(\xi-ct,t)-\psi(\xi)) \leqslant\lim\limits_{\xi\rightarrow+\infty}(v^{{\ast}}-\psi)=0. \end{align*}
Thus,
 \begin{equation*} \lim\limits_{\xi\rightarrow+\infty}B_1(\xi,t)={-}\mu-(1-k_1)+2u^{{\ast}}-k_1u^{{\ast}} -k_1v^{{\ast}}-\frac{rk_2}{4}+\frac{rk_2}{4}v^{{\ast}}. \end{equation*}
If
 \begin{equation} r<\frac{4(1-k_1)^{2}}{k_2(1-k_2)}, \end{equation}
then  $\lim \limits _{\xi \rightarrow +\infty }B_1(\xi ,t)>0$ for small
 $\mu >0$. Moreover, if (4.12) holds, then there are
 $K_{11}>0$ and
 $\xi _{41}$ such that for small
 $\mu >0$,
 \begin{equation} B_1(\xi,t)>K_{11},\qquad\xi\in(\xi_{41},+\infty). \end{equation}
Similarly, by noting
 \begin{equation*} \lim\limits_{\xi\rightarrow+\infty}B_2(\xi,t)={-}\mu+r+rk_2u^{{\ast}}-2rv^{{\ast}} -rk_2(1-v^{{\ast}})-\frac{k_1}{4}u^{{\ast}}, \end{equation*}
if
 \begin{equation} r>\frac{k_1(1-k_1)}{4(1-k_2)^{2}}, \end{equation}
then there are  $K_{12}>0$ and
 $\xi _{42}$ such that for small
 $\mu >0$,
 \begin{equation} B_2(\xi,t)>K_{12},\qquad\xi\in(\xi_{42},+\infty). \end{equation}
Let  $\xi _4=\max \{\xi _{41},\xi _{42}\}$ and
 $\tilde {\lambda }=\frac {c}{2}$. Then for
 $\xi \in (-\infty ,\xi _4)$, the inequality
 \begin{align} B_1(\xi,t)&=-\mu+\frac{c^{2}}{4}-(1-k_1)+2\phi-k_1\psi-k_1\phi-k_1V -\frac{r}{4}k_2(1-\psi)\nonumber\\ &\geqslant -\mu+\frac{c^{2}}{4}-(1-k_1)-k_1v^{{\ast}}-\frac{r}{4}k_2 \nonumber\\ &>K_{13} \end{align}
holds for some  $K_{13}>0$ and small
 $\mu >0$, if
 $c>c_1$, where
 \begin{equation} c_1=2\sqrt{1-k_1+k_1v^{{\ast}}+\frac{r}{4}k_2}. \end{equation}
Similarly, if  $0< d<2$ and
 $c>c_2$, where
 \begin{equation} c_2=\sqrt{\frac{8rk_2+k_1}{2-d}u^{{\ast}}}, \end{equation}
then the inequality
 \begin{align} B_2(\xi,t)&=-\mu+(2-d)\frac{c^{2}}{4}+r+rk_2\phi-2r\psi-rk_2(1-\psi)-\frac{k_1}{4}\phi -rV\nonumber\\ &\geqslant -\mu+(2-d)\frac{c^{2}}{4}-\left(2rk_2+\frac{k_1}{4}\right)u^{{\ast}}\nonumber\\ &>K_{14} \end{align}
holds for some  $K_{14}>0$ and small
 $\mu >0$. Thus if
 $0< d<2$, (4.12), (4.14) hold, and
 $c>\max \{c_1,c_2\}$, from (4.13), (4.15), (4.16) and (4.19), we have
 \begin{equation*} B_i(\xi,t)>0,\quad i=1,2,\enspace \xi\in\mathbb{R}. \end{equation*}
Therefore, from (4.11), one can conclude the following lemma.
Lemma 4.1 If  $0< d<2$ and
 $({k_1(1-k_1)}/{4(1-k_2)^{2}})< r<({4(1-k_1)^{2}}/ {k_2(1-k_2)})$, then for
 $c>\max \{c_1,c_2\}$ and small
 $\mu >0$, we have
 \begin{align} &\|U\|^{2}_{L^{2}_{\omega}}+\|V\|^{2}_{L^{2}_{\omega}}+\int^{t}_0 \textrm{e}^{{-}2\mu(t-s)}(\|U\|^{2}_{L^{2}_{\omega}}+\|V\|^{2}_{L^{2}_{\omega}})ds\notag\\ &\quad \leqslant M(\|U(0)\|^{2}_{L^{2}_{\omega}}+\|V(0)\|^{2}_{L^{2}_{\omega}})\textrm{e}^{{-}2\mu t}.
\end{align}
Remark 4.2 Taking  $k_1=k_2=\frac {1}{2}$ and
 $r=2$ fulfils the inequality
 $({k_1(1-k_1)}/ {4(1-k_2)^{2}})< r<({4(1-k_1)^{2}}/{k_2(1-k_2)})$.
Now we will give the  $L^{2}$-estimates of
 $U_{\xi }$ and
 $V_{\xi }$. Differentiating (4.4) with respect to
 $\xi$ gives
 \begin{equation}
\left\{ \begin{array}{@{}llll}
(U_{\xi})_t+c(U_{\xi})_{\xi}-(U_{\xi})_{\xi\xi}-A^{2}_{11}U_{\xi}
-A^{2}_{12}V_{\xi}=(k_1\psi'-2\phi')U+k_1\phi'V,\\
(V_{\xi})_t+c(V_{\xi})_{\xi}-d(V_{\xi})_{\xi\xi}+A^{2}_{21}V_{\xi}
-A^{2}_{22}U_{\xi}={-}rk_2\psi'U+r({-}k_2\phi'+2\psi')V,
\end{array} \right.
\end{equation}
where
 \begin{align*} &A^{2}_{11}:=A^{2}_{11}(\xi,t)=1-k_1-2U-2\phi+k_1V+k_1\psi,\\ &A^{2}_{12}:=A^{2}_{12}(\xi,t)=k_1(U+\phi),\\ &A^{2}_{21}:=A^{2}_{21}(\xi,t)=r(1+k_2U+k_2\phi-2V-2\psi),\\ &A^{2}_{22}:=A^{2}_{22}(\xi,t)=rk_2(1-V-\psi). \end{align*}
By multiplying the first equation of (4.5) by  $\textrm {e}^{2\mu t}\omega (\xi )U_{\xi }$ and the second equation of (4.5) by
 $\textrm {e}^{2\mu t}\omega (\xi )V_{\xi }$, similarly we have
 \begin{equation}
\left\{ \begin{array}{@{}llll} \dfrac{1}{2}(\textrm{e}^{2\mu
t}\omega
U^{2}_{\xi})_t+((A^{2}_{13})_{\xi}-A^{2}_{12}\omega
U_{\xi}V_{\xi}+A^{2}_{14} \omega
U^{2}_{\xi})\textrm{e}^{2\mu t}\\
\quad \leqslant
A^{2}_{15}\textrm{e}^{2\mu t}\omega
UU_{\xi}+A^{2}_{16}\textrm{e}^{2\mu t}\omega U_{\xi}V,\\ \dfrac{1}{2}(\textrm{e}^{2\mu t}\omega
V^{2}_{\xi})_t+((A^{2}_{23})_{\xi}-A^{2}_{22}\omega
U_{\xi}V_{\xi}+A^{2}_{24}\omega
V^{2}_{\xi})\textrm{e}^{2\mu t}\\
\quad \leqslant
A^{2}_{25}\textrm{e}^{2\mu t}\omega V
V_{\xi}-A^{2}_{26}\textrm{e}^{2\mu t}\omega UV_{\xi},
\end{array} \right.
\end{equation}
where
 \begin{align*} &A^{2}_{13}:=A^{2}_{13}(\xi,t)=\frac{c}{2}\omega U^{2}_{\xi}-\omega U_{\xi}U_{\xi\xi},\quad A^{2}_{23}:=A^{2}_{23}(\xi)=\frac{c}{2}\omega V^{2}_{\xi}-d\omega V_{\xi}V_{\xi\xi},\\ &A^{2}_{15}:=A^{2}_{15}(\xi,t)=k_1\psi'-2\phi',\quad\hspace{1.1cm} A^{2}_{25}:=A^{2}_{25}(\xi,t)=r({-}k_2\phi'+2\psi'),\\ &A^{2}_{16}:=A^{2}_{16}(\xi,t)=k_1\phi',\quad\hspace{2.2cm} A^{2}_{26}:=A^{2}_{26}(\xi,t)=rk_2\psi',\\ &A^{2}_{14}:=A^{2}_{14}(\xi,t)={-}\mu-\frac{c}{2}\frac{\omega'}{\omega} -\frac{1}{4}\left(\frac{\omega'}{\omega}\right)^{2}-1+k_1+2U+2\phi -k_1V-k_1\psi,\\ &A^{2}_{24}:=A^{2}_{24}(\xi,t)={-}\mu-\frac{c}{2}\frac{\omega'}{\omega} -\frac{d}{4}\left(\frac{\omega'}{\omega}\right)^{2}+r+rk_2U+rk_2\phi-2rV-2r\psi. \end{align*}
Then adding two inequalities of (4.22) and integrating over  $\mathbb {R}\times [0,\infty )$ with respect to
 $\xi$ and
 $t$, we have
 \begin{align} &\frac{1}{2}\|U_{\xi}\|^{2}_{L^{2}_{\omega}}\textrm{e}^{2\mu t}+\frac{1}{2}\|V_{\xi}\|^{2}_{L^{2}_{\omega}}\textrm{e}^{2\mu t}+\int^{t}_0\int_{\mathbb{R}}B_3(\xi,s) \textrm{e}^{2\mu s}\omega U_{\xi}^{2}\textrm{d}\xi \textrm{d}s\notag\\ &\qquad +\int^{t}_0\int_{\mathbb{R}}B_4(\xi,s) \textrm{e}^{2\mu s}\omega V_{\xi}^{2}\textrm{d}\xi \textrm{d}s\nonumber\\ &\quad \leqslant\frac{1}{2}(\|U_{\xi}(0)\|^{2}_{L^{2}_{\omega}}+\|V_{\xi}(0)\|^{2}_{L^{2}_{\omega}}) +\int^{t}_0\int_{\mathbb{R}}B(\xi,s)\omega \textrm{e}^{2\mu s}\textrm{d}\xi \textrm{d}s, \end{align}
where
 \begin{align*} B(\xi,t)&=A^{2}_{15}UU_{\xi}+A^{2}_{16}VU_{\xi}-A^{2}_{26}UV_{\xi} +A^{2}_{25}VV_{\xi},\\ B_3(\xi,t)&=-\mu-\frac{c}{2}\frac{\omega'}{\omega} -\frac{1}{4}\left(\frac{\omega'}{\omega}\right)^{2} -(1-k_1)+2U+2\phi-k_1\psi-k_1V-k_1U\\ &\quad -k_1\phi-\frac{rk_2}{4}(1-\psi-V),\\ B_4(\xi,t)&=-\mu-\frac{c}{2}\frac{\omega'}{\omega} -\frac{d}{4}\left(\frac{\omega'}{\omega}\right)^{2} +r+rk_2U+rk_2\phi-2rV-2r\psi-\frac{k_1}{4}U\\ &\quad -\frac{k_1}{4}\phi-rk_2(1-\psi-V). \end{align*}
Since  $\phi '$ and
 $\psi '$ are bounded for
 $\xi \in \mathbb {R}$, then there is a
 $M_0>0$ such that
 \begin{equation*} |k_1\psi'-2\phi'|,\quad|k_1\phi'|,\quad|rk_2\psi'|,\quad|-rk_2\phi'+2r\psi'|\leqslant M_0. \end{equation*}
By using the Young-inequality  $2xy\leqslant \beta x^{2}+({1}/{\beta })y^{2}$,
 $\beta >0$ and (4.20), we have
 \begin{align} \int^{t}_0\int_{\mathbb{R}}B(\xi,s)\omega \textrm{e}^{2\mu s}\textrm{d}\xi \textrm{d}s &\leqslant M_0\int^{t}_0\int_{\mathbb{R}}\left[\frac{1}{\beta}(U^{2}+V^{2}) +\beta(U^{2}_{\xi}+V^{2}_{\xi})\right]\omega \textrm{e}^{2\mu s}\textrm{d}\xi \textrm{d}s\nonumber\\ &\leqslant \frac{M_0M}{\beta}(\|U(0)\|^{2}_{L^{2}_{\omega}}+\|V(0)\|^{2}_{L^{2}_{\omega}}) \notag\\ &\quad +M_0\beta\int^{t}_0(\|U_{\xi}\|^{2}_{L^{2}_{\omega}}+\|V_{\xi}\|^{2}_{L^{2}_{\omega}})\textrm{e}^{2\mu s}\textrm{d}s, \end{align}
which implies that
 \begin{align} &\frac{1}{2}\|U_{\xi}\|^{2}_{L^{2}_{\omega}}\textrm{e}^{2\mu t}+\frac{1}{2}\|V_{\xi}\|^{2}_{L^{2}_{\omega}}\textrm{e}^{2\mu t}+\int^{t}_0\int_{\mathbb{R}}B_3(\xi,s) \textrm{e}^{2\mu s}\omega U_{\xi}^{2}\textrm{d}\xi \textrm{d}s\notag\\ &\qquad +\int^{t}_0\int_{\mathbb{R}}B_4(\xi,s) \textrm{e}^{2\mu s}\omega V_{\xi}^{2}\textrm{d}\xi \textrm{d}s\nonumber\\ &\quad \leqslant M(\|U(0)\|^{2}_{H^{1}_{\omega}}+\|V(0)\|^{2}_{H^{1}_{\omega}}) +M_0\beta\int^{t}_0(\|U_{\xi}\|^{2}_{L^{2}_{\omega}}+\|V_{\xi}\|^{2}_{L^{2}_{\omega}})\textrm{e}^{2\mu s}\textrm{d}s. \end{align}
It is easy to see that
 \begin{equation*} \lim\limits_{\xi\rightarrow+\infty}B_3(\xi,t) =\lim\limits_{\xi\rightarrow+\infty}B_1(\xi,t),\quad \lim\limits_{\xi\rightarrow+\infty}B_4(\xi,t) =\lim\limits_{\xi\rightarrow+\infty}B_2(\xi,t), \end{equation*}
which implies that, if (4.12) and (4.14) hold, then for small  $\mu >0$,
 \begin{equation} B_3(\xi,t)>K_{11},\qquad B_4(\xi,t)>K_{12},\qquad\xi\in(\xi_4,+\infty). \end{equation}
For  $\xi \in (-\infty ,\xi _4)$, similarly, by taking
 $\tilde {\lambda }=\frac {c}{2}$, we have
 \begin{align} B_3(\xi,t)&=-\mu+\frac{c^{2}}{4}-(1-k_1)+2U+2\phi\notag\\ &\qquad -k_1\psi-k_1V-k_1U-k_1\phi -\frac{rk_2}{4}(1-\psi-V)\nonumber\\ &\geqslant -\mu+\frac{c^{2}}{4}-(1-k_1)-k_1v^{{\ast}}-\frac{rk_2}{4} \nonumber\\ &>K_{13} \end{align}
for small  $\mu >0$, if
 $c>c_1$, and
 \begin{align} B_4(\xi,t)&=-\mu+(2-d)\frac{c^{2}}{4}+r+rk_2U+rk_2\phi-2rV\nonumber\\ &\quad -2r\psi-\frac{k_1}{4}U-\frac{k_1}{4}\phi-rk_2(1-\psi-V)\nonumber\\ &\geqslant -\mu+(2-d)\frac{c^{2}}{4}-2rv^{{\ast}}-\frac{k_1}{4}u^{{\ast}}\nonumber\\ &>K_{14} \end{align}
for small  $\mu >0$, if
 $0< d<2$ and
 $c>c_2$. Thus if
 $0< d<2$, (4.12), (4.14) hold, and
 $c>\max \{c_1,c_2\}$, from (4.26), (4.27) and (4.28), for small
 $\beta >0$, we have
 \begin{equation*} B_i(\xi,t)-M_0\beta>0,\qquad i=3,\ 4,\qquad\xi\in\mathbb{R}. \end{equation*}
Therefore, from (4.25), one can conclude the following lemma.
Lemma 4.3 If  $0< d<2$,
 $({k_1(1-k_1)}/{4(1-k_2)^{2}})< r<({4(1-k_1)^{2}}/{k_2(1-k_2)})$, then for
 $c>\max \{c_1,c_2\}$ and small
 $\mu >0$, we have
 \begin{align*} &\|U_{\xi}\|^{2}_{L^{2}_{\omega}}+\|V_{\xi}\|^{2}_{L^{2}_{\omega}} +\int^{t}_0\int_{\mathbb{R}} \textrm{e}^{{-}2\mu(t-s)}\omega(U_{\xi}^{2}+V_{\xi}^{2})\textrm{d}\xi \textrm{d}s\\ &\quad \leqslant M(\|U(0)\|^{2}_{H^{1}_{\omega}}+\|V(0)\|^{2}_{H^{1}_{\omega}})\textrm{e}^{{-}2\mu t}, \end{align*}
where  $M$ is a positive constant.
By lemmas 4.1–4.3, as we mentioned above, similarly to [Reference Mei, Lin, Lin and So15, Reference Yu, Xu and Zhang26], one can conclude the following global exponential stability theorem.
Theorem 4.4 Suppose  $0< d<2$,
 $({k_1(1-k_1)}/{4(1-k_2)^{2}})< r<({4(1-k_1)^{2}}/ {k_2(1-k_2)})$. Let
 $(\phi ,\psi )$ be a strictly increasing solution to (2.2)–(2.3) with the speed
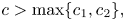 $c>\max \{c_1,c_2\},$ where
 \begin{equation*} c_1=2\sqrt{1-k_1+k_1v^{{\ast}}+\frac{rk_2}{4}},\qquad c_2=\sqrt{\frac{8rk_2+k_1}{2-d}u^{{\ast}}}. \end{equation*}
Assume the initial condition  $(u_0,v_0)$ in (4.1) satisfies
 \begin{equation*} (0,0)\leqslant(u_0,v_0)\leqslant(u^{{\ast}},v^{{\ast}}), \ \ u_0(x)-\phi(x), v_0(x)-\psi(x)\in H^{1}_{\omega}(\mathbb{R}), \end{equation*}
where  $\omega$ is given in (4.6). Then (2.1) with (4.1) admit a unique solution
 $(u,v)$ satisfying
 \begin{equation*} (0,0)\leqslant(u,v)\leqslant(u^{{\ast}},v^{{\ast}}), \end{equation*}
and
 \begin{equation*} u(x,\cdot)-\phi(x+c\cdot),\quad v(x,\cdot)-\psi(x+c\cdot)\in C([0,+\infty), H^{1}_{\omega}(\mathbb{R})). \end{equation*}
Moreover, the inequalities
 \begin{equation*} \sup\limits_{x\in\mathbb{R}}|u(x,t)-\phi(x+ct)|\leqslant M\textrm{e}^{-\mu t},\quad \sup\limits_{x\in\mathbb{R}}|v(x,t)-\psi(x+ct)|\leqslant M\textrm{e}^{-\mu t},\quad t>0 \end{equation*}
hold for some small  $\mu >0$ and
 $M>0$.


Acknowledgment
The present work is partially supported by the NSFC (11901366) and the NSFC (11971059), the Natural Science Foundation of Shanxi Province (201801D221008).


