INTRODUCTION
Water shortage severely depresses yields in many parts of the world. Increasing populations and diminishing supplies of geological water exacerbate the problem. Indeed, the Food and Agriculture Organization (FAO 2008) considers that 800 million people could be living under conditions of acute water scarcity by 2025. The scale of these problems is illustrated by the fact that world agriculture wastes (through inadequate water conservation, losses in distribution, and inappropriate times and rates of irrigation) 1500 trillion litres of water, 0·6 of the 2500 trillion litres of water it uses each year – which is 0·7 of the world's accessible water (Clay Reference Clay2004). In southern Europe, irrigation accounts for over 0·6 of the water use in most countries (European Commission 2000). The problems are enormous and require immediate remedies.
The comprehensive monograph by Stewart & Nielsen (Reference Stewart and Nielsen1990) gives an excellent account of the various factors influencing irrigation and how to improve irrigation efficiency of many crops. Recent attention has been given to improved cultural practices including subsurface irrigation (Banedjschafie et al. Reference Banedjschafie, Bastani, Widmoser and Mengel2008) and partial root zone drying irrigation (i.e. irrigating one side of a row crop while leaving the other side dry and then at the next irrigation irrigating the dry side and leaving the previously irrigated side dry; Saeed et al. Reference Saeed, Grove, Kettlewell and Hall2008). Considerable effort has also been devoted to developing drought resistant cultivars by conventional and genetically modified (GM) techniques (e.g. Farooq et al. Reference Farooq, Kobayashi, Wahid, Ito and Basra2009) and in the long term this could result in improved water use efficiency. However, there is still considerable uncertainty about how to adjust timing and rates of irrigation in different cropping systems. Practical advances in predicting irrigation requirements that are of wide applicability are needed. They could be applied immediately and be of immense benefit.
Recently, there have been substantial improvements in knowledge about the tolerance of crops to water deficit and about the ability of soils to supply water, which have led to the application of deficit irrigation (i.e. keeping the soil below field capacity during most of the growing season). Furthermore, advances have been made in understanding the soil–water–plant economy, firstly by the integration of this knowledge into simulation models, secondly by the improvement of sensor techniques for monitoring soil and plant water and, thirdly, by the introduction of wireless technology which facilitates the transmission of sensor data so that they can be used to control irrigation combined with technology that permits control of remote equipment. Although there have been many recent reviews on various aspects of irrigation (e.g. Debaeke & Aboudrare Reference Debaeke and Aboudrare2004; Bastiaanssen et al. Reference Bastiaanssen, Allen, Droogers, D'urso and Steduto2007; Costa et al. Reference Costa, Ortuño and Chaves2007; Fereres & Soriano Reference Fereres and Soriano2007; Steduto et al. Reference Steduto, Hsiao and Fereres2007), none brings together the aforementioned diverse aspects of sensor-driven irrigation. The objective of the present review is to do so, to identify opportunities for improvement and, especially, to highlight possible practical applications.
CURRENT IRRIGATION SCHEDULING
Irrigation practice is often dominated by the availability and cost of water. If water is readily available and cheap, its use is often profligate, with consequent environmental damage from leaching and soil compaction. In most of the world, however, there is a shortage of water but supply is often outside the control of the farmer who, therefore, usually accepts irrigation water whenever it is available, often when the crop does not need it (Jensen et al. Reference Jensen, Rangeley, Dieleman, Stewart and Nielsen1990). Applications of water are often not based on any objective assessment but are reliant on experience of what seems to have given good results in the past. Nevertheless, science-based methods of assessing irrigation needs have had an impact on practice. An early and most important contribution was the introduction of a formula (Penman Reference Penman1948), derived from considerations of energy and aerodynamics, for calculating evaporative loss from well-watered turf. The formula has been modified to the widely used Penman–Monteith equation (Monteith Reference Monteith1973; McNaughton & Jarvis Reference McNaughton and Jarvis1984), but the main principles remain. Evapotranspiration (ET) calculated in this way for turf is usually referred to as a reference ET; the meteorological inputs to the model are measured routinely in most meteorological stations. Pan evaporation (evaporation from a large pan of water) usually designated as E o is similar to that for well-watered turf and is also measured routinely (Hatfield Reference Hatfield, Stewart and Nielsen1990). However, the proportion of crop cover and the ‘surface roughness’ vary with crop species and development stage and are generally different from those of turf. To correct for these differences, ET is multiplied by a crop-specific coefficient, K c, the values of which have been tabulated for different crops during their growth (Allen et al. Reference Allen, Periera, Raes and Smith1998; Savva & Frenken Reference Savva and Frenken2002). Thus, if the aim of irrigation is to add sufficient water to compensate for that lost by ET, then this can be achieved approximately by adding an amount of water equal to that lost by the calculated ET (K c×ET), minus rainfall. A weakness of using this approach for estimating water loss over substantial periods is that errors are cumulative and so added irrigation water can become out of step with requirement (Jones Reference Jones2004). These methods have been used for estimating irrigation requirement by both full irrigation and deficit irrigation practices. In full irrigation, sufficient irrigation is applied to maintain the root zone soil near field capacity, a practice that results in excessive waste of water from drainage and from evaporation from the soil surface. In deficit irrigation, less water is applied than is needed to meet total losses from ET (Costa et al. Reference Costa, Ortuño and Chaves2007; Fereres & Soriano Reference Fereres and Soriano2007). Soil moisture deficit is important and can be defined as the volume of water needed to bring the soil to field capacity (the minimum water content at which free drainage can occur). The extent to which the soil moisture deficit can be allowed to fall without reducing crop growth varies depending on the crop species and its stage of development, and also on the environmental conditions: topics that are discussed in detail in the present review. Increased use of deficit irrigation promises to bring about considerable increases in water use efficiency.
Irrigation scheduling using plant-based methods has been comprehensively reviewed by Jones (Reference Jones2004). Several procedures for measuring plant water stress have been devised but they generally require a good deal of expertise to operate and, in any event, they do not indicate the water requirement. The most promising approach is thermal imaging. It is based on measuring the drop in temperature resulting from the evaporation of water. As loss of water from stomata is greater when they are open than when they are closed, temperatures are lower. The temperature difference, of course, also depends on the evaporative conditions in the surrounding atmosphere. Thus, the techniques have been a useful tool for irrigation scheduling in arid regions but less so in humid regions (Jones Reference Jones2004).
On the other hand, irrigation scheduling based on soil water has been widely reported. The distributions of water down soil profiles have long been measured gravimetrically and by neutron and capacitance probes. Soil water sensors that are inexpensive, convenient to operate and require little labour are being developed and are increasingly used commercially. Some of them are described later in the present review. Soil water has also been monitored remotely by microwave radar techniques (Ragab Reference Ragab1995; Clark et al. Reference Clark, Gowing, Lark, Leeds-Harrison, Miller, Wells, Whalley and Whitmore2005: Jadoon et al. Reference Jadoon, Slob, Vanclooster, Vereecken and Lambot2008; Lambot et al. Reference Lambot, Binley, Slob and Hubbard2008), generally for research and specialized purposes.
PLANT AND SOIL PROCESSES AFFECTING IRRIGATION REQUIREMENTS
Objectives for reducing the wastage of irrigation water include:
(1) reducing loss of water through evaporation from the soil surface;
(2) reducing leaching below the depth of rooting;
(3) allowing crops to exploit the water stored within the soil profile to the full depth of rooting; in many parts of the world, winter rain or monsoons bring the soil to field capacity and it is essential to make full use of this stored water;
(4) reducing the accumulation of salts within the soil profile that arise from excessive irrigation.
All four objectives can be met, at least partially, by reducing the total application of irrigation water. For example, if the frequency of irrigation is kept to a minimum then the surface soil will dry out and less water will be lost by evaporation from the soil surface.
Plant factors influencing irrigation need
Static maximum allowable soil moisture deficits
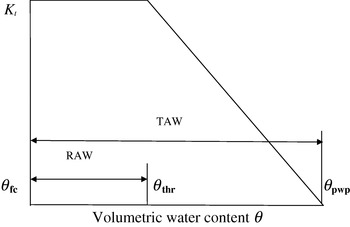
The key to minimizing irrigation without inhibition of growth is the often repeated finding that soils can lose considerable quantities of water without suppressing crop growth rate (Bailey Reference Bailey1990; Hills et al. Reference Hills, Winter, Henderson, Stewart and Nielsen1990; Krieg & Lascano Reference Krieg, Lascano, Stewart and Nielsen1990; Musick & Porter Reference Musick, Porter, Stewart and Nielsen1990; Bacci et al. Reference Bacci, Battista, Rapi, Sabatini and Checcacci2003; Panda et al. Reference Panda, Behera and Kashyap2003). Much effort has therefore been devoted to quantifying this phenomenon (Denmeade & Shaw Reference Denmeade and Shaw1962; Ritchie Reference Ritchie1973; Meyer & Green Reference Meyer and Green1980; Rosenthal et al. Reference Rosenthal, Arkin, Shouse and Jordan1987; Muchow & Sinclair Reference Muchow and Sinclair1991; Sadras et al. Reference Sadras, Villalobos and Fereres1993; Sadras & Milroy Reference Sadras and Milroy1996; Thompson et al. Reference Thompson, Gallardo, Valdez and Fernandez2007). A summary of this subject is given in the FAO irrigation manual (Allen et al. Reference Allen, Periera, Raes and Smith1998; Savva & Frenken Reference Savva and Frenken2002). It considers that soil water deficit does not inhibit growth unless it also inhibits ET. It is based on the assumption that crop ET remains constant with a decrease in available water until a critical value is reached, after which ET declines linearly with a further decrease in available water until the wilting point is reached, when ET ceases. It summarizes existing knowledge in terms of a maximum allowable soil moisture deficit, expressed as a proportion of the available water to the depth of rooting (MADP):
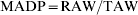
where TAW is the total available water in the root zone, i.e. between field capacity and the permanent wilting point. RAW, the readily plant available water, is the proportion of TAW that can be removed before transpiration and growth rates start to decline.
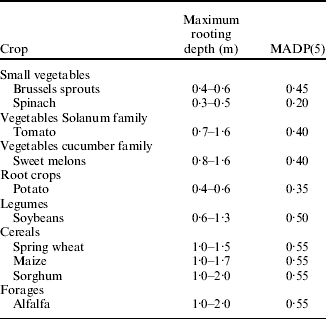
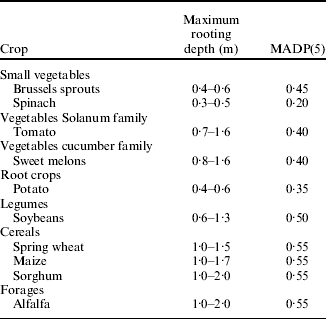
The concept is illustrated in Fig. 1. MADP depends on plant species and the evaporative conditions. Values of MADP standardized to a value of ET=5 mm/day (the reference ET) and referred to as MADP (5), have been provided by Allen et al. (Reference Allen, Periera, Raes and Smith1998) for 92 different crops. Examples are given in Table 1. Standardization to an ET of 5 mm/day was achieved using an equation that enabled values of MADP to be adjusted for differences in ET, over the range 0·1⩽MADP(ET)⩽0·8:
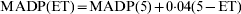
Schematic diagram of the effect of soil water content on crop transpiration. Kt is the transpiration rate (or growth rate) at the given water content expressed as a fraction of the rate when water is not limiting. θfc, θthr and θpwp are the water contents at field capacity, threshold and the permanent wilting point.

Some values of the maximum allowable deficit expressed as a proportion of the available water to the depth of rooting (MADP(5)) and standardized to an ET of 5 mm/day (after Allen et al. Reference Allen, Periera, Raes and Smith1998)
MADP(ET) is the value of MADP for a given value of ET in mm/day. Perhaps the equation should be treated with some caution as there has been a long-standing controversy about the dependence of MADP on ET (e.g. Denmeade & Shaw Reference Denmeade and Shaw1962; Ritchie Reference Ritchie1973). These estimates of the MADPs for different crops can only be approximate, because eqns (1) and (2) are assumed to hold for all soils and environments.
Dynamic maximum allowable soil moisture deficits
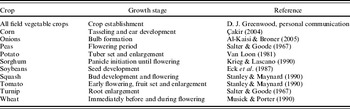
Implicit in the FAO tables of MADP(5) (Allen et al. Reference Allen, Periera, Raes and Smith1998) is that MADP(5) for each species is considered to remain constant throughout growth, even though it has long been established that the sensitivity of crop growth to soil water deficit varies during the growing season (Salter & Goode Reference Salter and Goode1967). Examples of the more sensitive stages of growth for a range of crops are given in Table 2 and emphasize that crops are particularly sensitive to water stress at flowering and seed development. Also, the method does not take account of the short-term changes in evaporative demand, plant water stress and growth rate during the growth period. The reason for the omission of these aspects from the FAO tables could be that the bulk of experiments on which they are based only reported the net effects of the average soil water deficit during growth on crop yields and provided little information on the short-term changes during the growing period. Typically in an irrigation experiment (Bailey Reference Bailey1990), treatments consisted of applying irrigation whenever the soil moisture deficit fell to each of different extents during growth. It enabled the minimum soil moisture deficit for maximum final yield to be estimated, which together with the depth of rooting gave the MADP.
Stages of growth that are particularly sensitive to water stress

One possible way of obtaining better information about changes during growth of allowable soil water deficits is to base it on the finding that, although growth increases almost asymptotically with increase in transpiration, growth and transpiration over a wide range of conditions are almost proportional to one another with a gradient that depends on evaporative conditions (Guitjens Reference Guitjens, Stewart and Nielsen1990; Steduto et al. Reference Steduto, Hsiao and Fereres2007). Thus in some lysimeter experiments, once there is complete crop cover of the soil, the rate of loss of water is assumed to be proportional to growth rate. Also the average soil water content can be estimated from the daily loss of water. Non-destructive measurements of transpiration and soil water content, as in some lysimeter experiments, can provide a good indication of changes in the sensitivity of growth to soil water deficit over much of the growing period.
Another approach to the problem is to relate surrogate measures of plant growth rate, such as the rate of leaf expansion, to plant available soil water (PAW) (Sadras & Milroy Reference Sadras and Milroy1996). Essentially, plant measurements are made at intervals over a period during which the soil water content declines in the depth of soil containing most roots. The rate of the surrogate process measured on the plant experiencing soil water deficit relative to that on those with no water deficit is considered to be unaffected by fall in water content until a threshold value is reached when the rate starts to fall. This threshold value and the corresponding apparent maximum allowable deficit, expressed as a fraction of the total available water, are determined. They are analogous to MADP and they are broadly consistent (Sadras & Milroy Reference Sadras and Milroy1996) with values of MADP referred to previously (Allen et al. Reference Allen, Periera, Raes and Smith1998).
The rooting depth problem
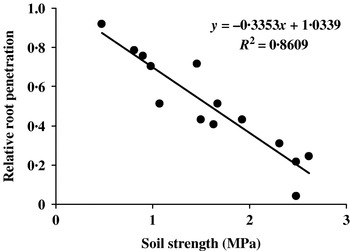
All the above methods suffer from the drawback that the amount of crop available water is critically dependent on the depth of rooting, which is often very difficult to estimate. A major problem in generalizing the results at one site to others is that rooting depths are very sensitive to soil conditions (Taylor & Gardner Reference Taylor and Gardner1963; Stalham et al. Reference Stalham, Allen, Rosenfeld and Herry2007). This is illustrated by Fig. 2, which shows that root penetration can vary by four-fold over the normal range of soil resistances induced by compaction and by reduced soil water content. Field experiments and surveys on 602 UK commercial fields of potatoes demonstrated that compaction resulted in shallower rooting than is desirable for efficient use of water and nutrients (Stalham et al. Reference Stalham, Allen, Rosenfeld and Herry2007). Practically useful models are needed to predict the effects of soil conditions on root growth over long periods. A possible way forward is suggested by the finding that penetrometer measurements can give a good measure of the effect of soil conditions on root growth at a point in time (Clark et al. Reference Clark, Gowing, Lark, Leeds-Harrison, Miller, Wells, Whalley and Whitmore2005). It may be possible to develop models for the dependence of penetrometer readings, and thus root penetration, on soil texture, bulk density, organic matter content and soil water content. This would provide a means of estimating the time-course of soil conditions and their effects on root penetration.
Effect of soil strength on root penetration of cotton seedling tap roots. Different soil strengths were created by modifying bulk density and soil water content; both variables affected the dependence of root penetration on soil strength similarly. (The figure is derived from Taylor & Gardner Reference Taylor and Gardner1963.)

A new procedure for measuring the maximum allowable deficits without any explicit requirement of rooting depth was introduced by Thompson et al. (Reference Thompson, Gallardo, Valdez and Fernandez2007) for crops in a 400 mm deep soil. Measurements are made of volumetric water content to this depth every 30 min. The loss of water is partitioned into drainage and transpiration losses by considering that only drainage loss occurs at night. It is considered that when transpiration loss is divided by ET starts to fall, growth is inhibited by soil water deficit and thus the MADP can be calculated from the corresponding soil water content. The idea that the net changes in soil water content from drainage (and also from evaporation) can be assessed from measurements during the night might have wider applications. They may be relevant to estimating the depth of rooting from sensor measurements of soil water down the soil profile. The depth of rooting is sometimes taken as the maximum depth at which soil water content declines according to measurements at a given time of day. This could be due to a combination of transpiration, drainage and other soil processes affecting water movement. Ideally what is required is the depth from which transpiration removes water. By taking account of changes in soil water during the night, it should be possible to separate the changes due to soil processes from those due to transpiration and thus obtain a more reliable measure of rooting depth.
Soil factors affecting irrigation need
Soil variability across the field
A major limitation for irrigation efficiency of many arable crops can be differences in irrigation requirement across fields, which are associated with variations in soil hydraulic properties (Ahuja & Nielsen Reference Ahuja, Nielsen, Stewart and Nielsen1990). Ideally measurements of hydraulic properties over the irrigated area need to be made and interpreted with kriging techniques to produce contour diagrams of the variation in hydraulic conductivity. These measurements are, however, too costly and there is a need for short-cut, cheaper procedures. Soil surveys provide data on soil properties to depth, which is important as deep-rooted crops can extract much water from the subsoil. Information gained in this way, or even better by direct measurement, about particle size distributions, bulk density and soil organic matter content can be used to infer soil hydraulic properties by means of pedo-transfer functions (PTFs). Several PTFs have been proposed including those based on the HYPRES database (Lilly et al. Reference Lilly, Wösten, Nemes, Le Bas, van Genuchten, Leij and Wu1998), which covers different European soils (Wösten et al. Reference Wösten, Lilly, Nemes and Le Bas1999). Thermal imaging (Jones Reference Jones2004), airborne radiometric surveys (Rawlins et al. Reference Rawlins, Marchant, Smyth, Scheib, Lark and Jordan2009) and grain yields, which are often measured routinely across fields by farmers, can also provide useful information.
Water use efficiency could be improved by monitoring soil water contents down the soil profile, at different locations, and adjusting irrigation practice accordingly. In practice, it seems too time consuming and costly to do this manually, with a neutron probe or similar device but, as will be shown later, it should be possible to do so, relatively cheaply, using soil water sensors combined with wireless technology.
Distribution of irrigation water
Another cause of variation is that most irrigation equipment does not distribute water uniformly (Losada et al. Reference Losada, Juana and Roldán1990); consequently application of the amount of water required to meet the average soil moisture deficit results in too little water being applied at some locations and too much in others, with consequent leaching and waste of water. Poor water use efficiency can also be caused by irrigation failing to intercept plant roots. While this is not a problem with drip irrigation, it is a problem especially with boom irrigation of widely spaced crops and of pot and container plants, because a large proportion of the irrigation misses the plants.
Infiltration of water into soil
Effective irrigation requires that water penetrates soil rapidly. It is particularly important for deep-rooted crops. The strategy for conserving water in deep-rooted soils consists of heavy applications of water, albeit occasionally. Thus, it is essential that the soil permits rapid infiltration of water over long periods, as occurs in well-structured soils. Rates of infiltration into some soils, however, fall very sharply to a low value shortly after the start of irrigation (Kruse et al. Reference Kruse, Bucks, Von Bernuth, Stewart and Nielsen1990). Slow rates can usually be attributed to compaction and small water-filled pores, through which water can pass only slowly, but it can also result from the soil surfaces being water-repellent (Bryant et al. Reference Bryant, Doerr, Hunt and Conan2007). Water repellency occurs worldwide (Dekker et al. Reference Dekker, Oostindie and Ritswia2005), probably because of the deposition of hydrophobic organic materials on soil surfaces (Debano Reference Debano1971; Nannipieri & Badalucco Reference Nannipieri, Badalucco, Benbi and Nieder2003). In addition, some bacteria can produce extracellular polymeric substances in soil that can bring about a four-fold reduction in hydraulic conductivity (Or et al. Reference Or, Phutane and Dechesne2007).
Irrigation and rain can lead to surface sealing in some soils (e.g. Silva Reference Silva2007); the process results from disintegration of soil crumbs, swelling of soil colloids and entrapment of air (Payne Reference Payne and Wild1988). It has long been recognized as a major problem and it has been alleviated in soils by application of soil conditioners (Ben-Hur et al. Reference Ben-Hur, Faris, Malik and Letey1989) and by various soil management practices (Abrisqueta et al. Reference Abrisqueta, Plana, Mounzer, Mendez and Ruiz-Sanchez2007). Barriers to water penetration can of course also occur within the body of the soil profile. Well-known examples are plough and iron pans (Avery Reference Avery1990). However, such restrictions can also occur for less well-understood reasons; thus when a limited volume of water is added to some soils the water content is brought to a uniform water content to a given depth but there is a sharp boundary between this wetted soil and the un-wetted soil beneath it (Russell Reference Russell1973). The sharp transition could result from the hysteresis of the soil moisture release curve (Warrick Reference Warrick, Stewart and Nielsen1990), where the relation between water content and water potential differs depending on whether the dry soil is wetted or whether the wet soil is dried. Water moving from the wet soil to the dry soil beneath consists of desorped water moving to sorped water. The water content on the wet side could be much greater than on the dry side but, owing to hysteresis, both have the same water potential and thus there is no transfer of water. Inducing some soils to accept substantial volumes of water can be difficult but a procedure which consisted of drilling holes to a depth of 600 mm, filling them with sand and then irrigating (Abu-Awwad Reference Abu-Awwad1998) has resulted in deep penetration of water and good crops on an impermeable soil.
Models for infiltration are of two types. One consists of empirical relationships between various measurements for a particular area. The other is derived mechanistically from the Richards' equation and some of these models take account of hysteresis (Hanks & Cardon Reference Hanks, Cardon, Benbi and Neider2003). As far as the authors are aware, however, none takes account of soil water repellency.
SENSORS
Required characteristics
Soil water sensors need to measure soil water content or the corresponding soil water potential over the ranges that are found in practice. A recent survey of the MADP(5) of 22 different crop species gave 72 values that ranged from 0·05 to 0·81 with 26 values being greater than 0·5. The majority of MADP(5) were therefore less than 0·5 (D. J. Greenwood, personal communication). A proportion of 0·5 of the maximum available water corresponds to a water potential of approximately −20 kPa for a loamy sand soil and −200 kPa for a clay soil. A different survey gives 33 values of the soil water potentials that have been found to be necessary for good growth of 16 species but only 6 were less than −200 kPa (D. J. Greenwood, personal communication). The results from the two surveys are broadly consistent with one another and suggest that water potential sensors over the range 0 to −200 kPa should cover most requirements. These values are, however, averages, and water is unevenly distributed down the soil profile so the water potential in a specific position, say at the uppermost sensor, could be much lower than −200 kPa. Variations between sensors of the same type in their responsiveness to soil water should be small otherwise the cost of calibration could be considerable. Ideally sensors should need no calibration by the user, and it is notable that according to Decagon Devices (2009) one of their sensors meets this requirement.
There is no advantage of using sensors that measure water content over those that measure water potential because the ability of a given soil to supply water to plant roots is governed by both water potential and water content. Irrigation requirement is dependent on soil water content at field capacity and the threshold value. Thus whichever type of sensor is used the soil moisture release curve is required to calculate the missing parameter and thus the irrigation requirement.
Available sensors
Numerous sensors for monitoring soil water are presently available. There are two main types; those that measure soil water content and those that measure soil water potential. The majority of the former actually measure the dielectric constant of soil, which is largely determined by its water content. One type of dielectric sensor, the frequency domain reflectometer (FDR), also referred to as a capacitance sensor, adjusts the frequency of an oscillating voltage until it identifies the strongest resonating frequency, which is a measure of the dielectric constant and thus the water content of the soil. Another type of dielectric sensor uses the technology ‘time domain reflectometry’ (TDR) to measure the dielectric constant, as the time taken for an electromagnetic pulse travelling down a rod to be reflected along its precise length. Both types of sensor, although expensive, measure a wide range of bulk soil water contents. They can also respond quickly to changes in soil water content (Campbell & Anderson Reference Campbell and Anderson1998; Evett & Parkin Reference Evett and Parkin2005; Nemali & Iersel Reference Nemali and Iersel2006). However, there is evidence that the performance of some sensors may vary with the soil conditions; one commercially available capacitance probe did not give reliable absolute measurements of soil water content although it enabled relative changes in soil water content over time to be estimated (Mwale et al. Reference Mwale, Azam-Ali and Sparkes2005). Although they do not always give reliable measurements of soil water content, dielectric sensors are generally chosen where there is a requirement to measure small but rapid changes in soil water contents needed for precise control of water addition to soil, e.g. in container cropping where volumes of soil are small and it is essential to maintain soil water contents close to a constant value, despite sudden variations in evaporative conditions that in the absence of irrigation would cause rapid changes in soil water content.
Moisture sensors that measure water potential are numerous. However, prominent among sensors that have been used to measure water potential in field soils are granular matrix sensors. Essentially, they consist of two concentric electrodes embedded in a reference matrix material, which is surrounded by a synthetic membrane for protection against deterioration (Chard Reference Chard2005). When a sensor is put into moist soil, the matrix water equilibrates with that in soil. Absorption of water increases the electrical conductivity of the matrix and the water potential of the soil can be calculated from this. Such sensors are comparatively inexpensive, have a range of 0 to −240 kPa, can measure water potentials in small volumes of soil and have functioned satisfactorily in soil for 3·5 years after installation (Qualls et al. Reference Qualls, Scott and Deoreo2001). They are, however, slow to respond to changes in soil water content, especially in drier soils. Granular matrix sensors are usually chosen when soil water changes are gradual, where many sensors are required to monitor soil water to depth over considerable areas and where satisfactory sensor performance over a long period is required.
A novel and probably more accurate sensor for measuring soil water potential consists of porous material that equilibrates with the soil water and a dielectric device that measures the water content of the porous material. A closed-form of hysteresis loop is used to convert the measured water content of the porous material into water potential. The use of two ceramic materials instead of one enables the sensor to measure matric soil water potentials over the approximate range −10 to −200 kPa (Whalley et al. Reference Whalley, Watts, Hilhorst, Bird, Balendonck and Longstaff2001, Reference Whalley, Clark, Take, Bird, Leech, Cope and Watts2007, Reference Whalley, Lock, Jenkins, Peloe, Burek, Balendonck, Takei, Tuzel and Tuzel2009).
Practical experience in the use of sensors
Much experience has been gained in the use of soil water sensors, from which the following practical advice on their use has emerged.
(a) Sensors must be calibrated for the given soil before use. Problems can arise, however, because of failure to recognize that soil water potential sensors can only operate over a limited range of water potentials and that equilibration times can be considerable. Manufacturers of some types of sensors provide experimental protocols for deriving calibration equations and others are published in the scientific literature (e.g. Geesing et al. Reference Geesing, Bachmaier and Schmidhalter2004; Groves & Rose Reference Groves and Rose2004). In addition to calibration, it is also important to check the specifications to ensure that the sensor is suitable for the proposed application and soil.
(b) Failure to ensure adequate contact between the sensor and surrounding soil is a serious and widespread problem. Protocols for embedding sensors in soil (Allen et al. Reference Allen, Periera, Raes and Smith1998; Savva & Frenken Reference Savva and Frenken2002) are especially important for small sensors as it is easy to damage the ceramics (Bacci et al. Reference Bacci, Battista, Rapi, Sabatini and Checcacci2003), which results in poor contact with the soil. Dielectric sensors must be maintained in close contact with soil otherwise measurements can be largely dominated by air gaps between sensor and soil.
(c) Failure to include a means of detecting sensor or electronic malfunction and an associated routine for automatically cutting off the irrigation can result in considerable waste of water (Qualls et al. Reference Qualls, Scott and Deoreo2001).
(d) The presence of roots around sensors can, if the sensors are small, result in their outputs losing sensitivity to changes in soil water, possibly because the sensors become coated with material that is impermeable to water (Bacci et al. Reference Bacci, Battista, Rapi, Sabatini and Checcacci2003).
IRRIGATION SCHEDULING BY SOIL WATER SENSORS
The use of sensor-based procedures varies enormously with the type of crop and the environment. Sensor technology has been used at one extreme for crops grown for short periods, in limited volumes of soil and under high evaporative conditions, and at the other extreme for field crops grown over long periods in deep soils from which the roots extract water up to 2 m from the surface. These differences result in variations in sensor costs and in their performance.
Shallow-rooted crops
Typical examples are container crops, lawns and urban landscapes, as the rooting depths are often no more than about 200 mm, often because they overlay a very compact soil layer, or an extremely stony horizon that is a barrier to root penetration. The water contents in such soils change very quickly and water needs to be added frequently so as to ensure that the plant is never restricted by a temporary soil water deficit and yet ensure there is only minimal drainage. Soil water sensors at only one depth are required for these cropping systems.
Horticultural plants, such as ornamentals for the retail market, are grown in containers under evaporative conditions that are often high and vary during the day and from day to day. Efficient irrigation practice has included taking readings at a specific time of day and adjusting irrigation practice for the evaporative conditions (Klein Reference Klein2004). The amount of water that can be held in the rooting medium for container crops is small so the water content can change quickly. What is required is a way of maintaining the soil water at a constant value irrespective of changes in weather conditions, an objective that has been achieved by Nemali & Iersel (Reference Nemali and Iersel2006) who devised a system in which a controller uses dielectric substrate moisture sensors interfaced with a data logger and solenoid valves that supply irrigation. Measurements of substrate water were made every 20 min, which enabled the substrate water content to be maintained within 2–3% of the target value over 40 days. The key to success was the use of a very rapidly responding dielectric sensor.
Sensor-driven irrigation systems for urban landscapes in China and the USA are described in a number of papers (e.g. Qualls et al. Reference Qualls, Scott and Deoreo2001; Guo et al. Reference Guo, Zheng, Zhao, Li and Wang2005). Scheduled irrigations have been based on applying sufficient water to compensate for estimates of water loss from evaporative demand. However, in one system (Qualls et al. Reference Qualls, Scott and Deoreo2001) granular matrix sensors (Watermark) were embedded in soil at different points within the area and transmitted their readings by wire to an electronic module that either allows or prevents a scheduled irrigation cycle depending on the soil moisture condition. The system was adopted on 22 sites of average area 2177 m2, and resulted in an average reduction of 27% of water applied and savings of $US 331/yr per sensor.
Irrigation of lawns has, as for urban landscapes, been based on supplying sufficient water to compensate for estimated evaporative demand. It can result in excessive drainage losses. To prevent such losses, sensors that detect free water are embedded in soil at a suitable depth and when they indicate the presence of free water they send a signal that cuts off the irrigation supply (Stirzaker & Hutchinson Reference Stirzaker and Hutchinson2005). A rather more sophisticated system has been reported, using a simulation model to estimate water requirement together with a subsurface time domain sensor to monitor soil water content (Blonquist et al. Reference Blonquist, Jones and Robinson2006). Its use resulted in 53% less irrigation than the currently recommended fixed rate of 50 mm water/week and also resulted in no detectable drainage below 300 mm from the surface.
Few papers in the literature are on sensor-controlled irrigation of field crops that penetrate to only a shallow depth. One such paper (Kang & Wan Reference Kang and Wan2005) related the growth and quality of radish (Raphanus sativus L.) to sensor-measured water potentials at 200 mm from the surface. It reported that although maintaining water potentials at each of different values over the range −15 to −65 kPa had no effect on yield, they did affect root cracking, which is an important quality attribute. A literature review of irrigation scheduling controlled by soil water sensors at a depth of approximately 250 mm also indicated that good growth of a variety of crops required a water potential greater than −65 kPa (Boote & Ketring Reference Boote, Ketring, Stewart and Nielsen1990; Stanley & Maynard Reference Stanley, Maynard, Stewart and Nielsen1990; Wright & Stark Reference Wright, Stark, Stewart and Nielsen1990; Munoz-Carpena et al. Reference Munoz-Carpena, Dukes, Li and Klassen2005; Wang et al. Reference Wang, Kang, Liu and Hou2007). It is possible that at least some of these crops are deep-rooted.
As mentioned earlier, sub-surface drip irrigation (Banedjschafie et al. Reference Banedjschafie, Bastani, Widmoser and Mengel2008) can improve water use efficiency by minimizing evaporation from the soil surface. It is notable that water sensors at only 50 mm depth have been effectively used to control decisions by irrigation from drip tapes installed 250–300 mm from the soil surface (Nogueira et al. Reference Nogueira, Dukes, Haman, Scholberg and Cornejo2003). Sensors at shallow depths within the soil profile can therefore provide useful information for irrigation scheduling.
Deep-rooted agricultural crops
Limited support for the view that sensor determinations at about 250 mm depth may provide a useful indication of irrigation need of some deeper rooted crops is provided by Stieber & Shock (Reference Stieber and Shock1995). These authors concluded that irrigation of potatoes could best be determined by maintaining soil water potential above −59 kPa with sensors at a single depth of between 0·1 and 0·2 m, offset from the centre of the ridge.
Crops with roots that penetrate to a depth of 1–2 m can, if the soil conditions are satisfactory, extract water to that depth. Many such soils are at near field capacity immediately before planting, often as a result of winter rainfall or monsoon rains. Considerable soil water deficits can occur on such soils without growth being inhibited. Irrigating according to the distribution of soil water down the profile so as to make maximum use of the stored water could therefore enable substantial saving of irrigation water. As irrigation would be infrequent, the surface of the soil would be dry for long periods which would reduce evaporation from it. For these reasons, some growers have been using sensors to monitor soil water at different depths down the profile and using the information obtained to schedule irrigation as described by free advice from extension services (Thomson & Ross Reference Thomson and Ross1996; Werner Reference Werner2002).
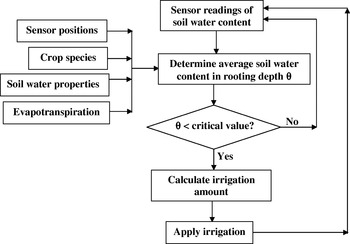
Estimation of when and how much irrigation is required for deep rooted crops can be based on MADP using the information and sequence of decisions summarized in Fig. 3. Determinations of the rooting depth and volumetric water content to that depth require further explanation. Thomson & Ross (Reference Thomson and Ross1996) inferred the rooting depth from soil water distribution measured by sensors. Other workers deduced the time course of the depth of rooting from mean daily temperatures (Pedersen et al. Reference Pedersen, Zhang, Thorup-Kristensen and Jensen2009) or an algorithm that enables the rooting depth to be calculated from plant dry weight (excluding fibrous roots), depth of rooting at final harvest and an equation that defines the increase in plant dry weight with time (e.g. Greenwood et al. Reference Greenwood, Cleaver, Loquens and Niendorf1977, Reference Greenwood, Gerwitz, Stone and Barnes1982; Zhang et al. Reference Zhang, Greenwood, White and Burns2007). The average volumetric water content to the depth of rooting can be calculated from the measured soil water potentials down the profile and the soil water release curves. These calculations can be aided by models that are subsequently described.
Flow chart of irrigation scheme based on sensor readings and model predictions.

WIRELESS TECHNOLOGY
Wireless data acquisition and control systems (WDAC) will have an increasing impact on many aspects of crop production. They enable data obtained from sensors or data loggers to be received and facilitate remote control of a device through standard telephone lines, computers or other communication systems. Wireless technology is widely used in spatial data collection, variable rate technology and in disseminating information (Wang et al. Reference Wang, Zhang and Wang2006). Using WDAC systems to control irrigation should enable
(i) equipment to be remotely, and possibly automatically operated, for example from a control centre on the basis of the sensor data (Damas et al. Reference Damas, Prados, Gómez and Olivares2001);
(ii) sensor readings at different depths and in different locations within a field to be transmitted at predetermined times to a control centre where they are processed, and possibly used to control equipment;
(iii) real time data to be made available over the Internet (Shukla et al. Reference Shukla, Yu, Hardin and Jaber2006).
Much less work has been published on the use of WDAC systems for the control of equipment than for the acquisition of data. Remote wireless controls of a central pivot irrigation system (Pocknee et al. Reference Pocknee, Garrick, Kvien and Mulla2004) and of drip line irrigation (Coates et al. Reference Coates, Delwiche and Brown2006) are examples of the few publications of wireless control systems. By contrast, a literature search (D. J. Greenwood, personal communication) revealed 16 papers describing successful wireless data acquisition systems (e.g. Bratton et al. Reference Bratton, Shinn, Farrington and Bianchi2000; Cao et al. Reference Cao, Xia and Zhu2005; Kim et al. Reference Kim, Evans and Iversen2008; Vellidis et al. Reference Vellidis, Tucker, Perry, Kvien and Bednarz2008). It seems that problems of installing effective wireless acquisition systems have been largely solved but there are still technical problems in wireless control of remote equipment. An encouraging development is that a US Department of Agriculture (USDA) group is studying wireless based irrigation control of self-propelled linear-movement and centre-pivot irrigation equipment (Wang et al. Reference Wang, Zhang and Wang2006).
Recent advances for field crops include a wireless sensor means of scheduling irrigation for field crops described by Vellidis et al. (Reference Vellidis, Tucker, Perry, Kvien and Bednarz2008). It also has the merit of being inexpensive. There are three major components: nodes that are distributed throughout the field and a base station that consists of a receiver to accept wireless signals from the nodes and a laptop computer to process the signals. At each node, sensors monitor soil water potential at depths of 0·2, 0·4 and 0·6 m from the soil surface. They are connected by wire to a specially designed smart circuit board, mounted on top of a flexible rod, which at predetermined times obtains readings from each of the sensors, activates a radio frequency identification tag (RFID) and transmits the data to the base station; during the remaining periods the node ‘sleeps’, does not use power, and over the entire growing period only requires a single 9V lithium battery. The transmitter has a range of 0·8 km provided there are no obstructions in the line of site to the base station. The procedure was tested in a cotton field in which there were four different soil types. It appeared to give excellent measurements of the distributions of soil water potential down the profiles in each of them. In addition, outputs from the laptop have been linked to a variable rate central pivot irrigation system so as to supply water at rates according to the needs of individual areas within fields. Complete systems of sensors, wireless transmitters and receivers are now available commercially (Decagon Devices 2009) and integrated wireless communication and data logger systems are also on the market (Shukla et al. Reference Shukla, Yu, Hardin and Jaber2006).
Improvements in commercial wine production have been achieved by controlling irrigation with high density multiple depth soil moisture sensors and transmitting the outputs by wireless communication at 10 min intervals to a central PC for processing and storage on a database and estimating irrigation requirements. It was also transmitted to the internet via satellite where it is available online (Holler Reference Holler2008; Ulrich Reference Ulrich2008).
A major opportunity for advancement in sensor-controlled irrigation is provided by recent research in wireless sensor networks which is impacting on many subjects. Essentially, it is concerned with the design of networks in which some of the nodes can communicate with each other so that information can travel over short distances (requiring little battery power) from node to node until it reaches a base station. This enables low-cost sensors to be distributed over a wide area and results in long battery lives at the nodes and therefore little maintenance (Hart & Martinez Reference Hart and Martinez2006).
Wireless technology has recently been introduced into glasshouse cropping to facilitate the retrieval of sensor information. Prior to this innovation, sensor-driven irrigation has involved extensive wiring that degrades under these conditions, requires substantial maintenance and is quite impracticable in modern large glasshouse systems. In consequence, current work is focused on devising combined wireless–transmitter–sensor modules that are distributed throughout the glasshouse and that transmit to a computer-controlled irrigation system (Cayanan et al. Reference Cayanan, Dixon and Zheng2008). Such wireless-soil water sensor systems for glasshouses are now marketed commercially (Hoogendoorn Growth Management 2008).
QUANTITATIVE MODELS
Simulation models for soil water and its effect on crop growth
Principles about water dynamics in the soil–crop system, such as those described above, have been encapsulated into simulation models that calculate changes in soil water and plant growth over time. The models are of varying complexities and include SWATRE (Belmans et al. Reference Belmans, Wesseling and Feddes1983), CROPWAT (Clarke Reference Clarke1998), IRSIS (Raes et al. Reference Raes, Lemmens, Van Aelst, Vanden Bulcke and Smith1988) and SWAP (Kroes et al. Reference Kroes, Van Dam, Groenendijk, Hendriks and Jacobs2008). They aim to provide a widely applicable means of estimating water distributions down the soil profile and their effects on plant growth. SWAP is one of the most sophisticated models of its kind. The model simulates transport of water, solutes and heat in the vadose zone interactively with the development of vegetation. The governing equation for soil water flow is solved using an implicit finite difference method. The model has been widely tested and has given promising results. However, such a complex model requires many data inputs, which could cause difficulties for any user who does not have an excellent knowledge of soil and plant sciences. Furthermore, the adopted chosen numerical scheme is associated with instability. The most recent model, AquaCrop, developed by FAO (Hsiao et al. Reference Hsiao, Heng, Steduto, Rojas-Lara, Raes and Fereres2009; Raes et al. Reference Raes, Steduto, Hsiao and Fereres2009a, Reference Raes, Steduto, Hsiao and Fereresb; Steduto et al. Reference Steduto, Hsiao, Raes and Fereres2009), simulates the effects of the aerial environment and soil water on plant processes. The model updates a range of variables for each day. It calculates canopy cover, root distribution, stomatal opening, the roots' ability to meet transpiration demand and transpiration. Each of these variables depends to different extents on thermal time, potential ET and the fraction of available soil water to the depth of rooting. Plant biomass is calculated from transpiration and is modified for atmospheric CO2 and soil fertility. Water evaporates from the soil surface that is not covered by crop canopy. Water movement throughout the body of soil is calculated by a cascade method using semi-empirical algorithms. The model has been calibrated and tested against field experimental data for some crops with promising results (e.g. Farahani et al. Reference Farahani, Izzi and Oweis2009; Hsiao et al. Reference Hsiao, Heng, Steduto, Rojas-Lara, Raes and Fereres2009). In the model, soil water is central to controlling crop growth, but the treatment of soil movement using a cascade method appears to be questionable for some circumstances such as where there is a relatively high groundwater table and upward capillary flow makes an important contribution towards meeting ET. Further, the model requires a large number of inputs which are often difficult to obtain, such as those associated with soil water movement. Cascade methods, though easy to implement, are associated with unsatisfactory simulations of capillary flow and poor predictions of daily soil water changes (Gandolfi et al. Reference Gandolfi, Facchi and Maggi2006; Cannavo et al. Reference Cannavo, Recous, Parnaudeau and Reau2008; Yang et al. Reference Yang, Zhang, Zhang, Greenwood, Hammond and White2009). If a way could be found of replacing the cascade method in the AquaCrop model with ones based on the fundamental theory of soil water movement, then the resulting model might be more widely applicable than the current version.
Application of classical theory of soil water movement
Application of this theory, besides improving existing models for water dynamics in the soil–crop system, is also important for interpreting soil water sensor data. Although there are many situations where soil water content increases with depth and the total soil moisture deficit can be readily obtained from the integral of a fitted empirical equation between sensor measured soil water content and depth, there are other situations where the patterns are complex and the fitting procedure is unsatisfactory, especially when soil sensors are few. Also it is always difficult, from soil sensor measurements, to distinguish between evaporative and drainage losses and crop transpiration.
The key to solving these problems probably lies in applying classical theory of soil water transport, despite complications associated with the dependence of the soil water release curve on changes in bulk density after cultivation and on whether the soil water content is rising or falling (Warrick Reference Warrick, Stewart and Nielsen1990). Classical theory is encapsulated in the Richards' equation (Bastiaanssen et al. Reference Bastiaanssen, Allen, Droogers, D'urso and Steduto2007; Yang et al. Reference Yang, Zhang, Zhang, Greenwood, Hammond and White2009). The equation is differential and highly non-linear and until recently complex procedures were required to solve it. Often their use requires specialized expertise that many potential users lack, which could explain why the cascade method for soil water movement is still favoured in many crop models used to solve practical problems.
The extremely rapid rate of computing by PCs provides an alternative and easy-to-use means of solving the Richards' equation (Lee & Abriola Reference Lee and Abriola1999). The essential idea behind the advance can best be understood by simulating water movement down a column consisting of sequential soil layers with uniform thickness. It is assumed that at any instant although the average water contents in each layer may differ, the water within each individual layer is uniformly distributed. Water flows between adjacent layers are according to the flow equation. The calculations are repeated for a very small time step, in the order of 0·001 days, and give estimates of water distribution that are similar to those obtained by solving the Richards equation using the finite-element method.
A new model, by extending the work by Lee & Abriola (Reference Lee and Abriola1999), has recently been constructed for simulating water dynamics in the soil–crop system (Yang et al. Reference Yang, Zhang, Zhang, Greenwood, Hammond and White2009). The model treats infiltration of water into the surface layer and evaporation from it; it also includes algorithms for root growth and the associated transpiration. Potential evaporation and transpiration are estimated from Allen et al. (Reference Allen, Periera, Raes and Smith1998). Soil hydraulic functions are those defined by Mualem (Reference Mualem1976) and Van Genuchten (Reference Van Genuchten1980). Simulations with the model of the distributions of water down the soil profile in different cropped soils at time intervals during growth were in excellent agreement with measurements (Yang et al. Reference Yang, Zhang, Zhang, Greenwood, Hammond and White2009). The model as such could be used to predict irrigation requirements as shown in Fig. 3.
In the sensor-based irrigation system, a model of this kind can be calibrated against the sensor data and then used to calculate the daily distributions of water down the profile and the evaporative and drainage losses. To calibrate the model, inverse modelling techniques, based on optimization theory to obtain the best fit between simulation and measurement, could be used to estimate uncertain parameter values. One possible set of parameters for such estimation are those defining soil hydraulic properties which are often determined by PTFs in terms of percentages of clay, silt, and soil organic matter and bulk densities as proposed by Wösten et al. (Reference Wösten, Lilly, Nemes and Le Bas1999) and Cresswell et al. (Reference Cresswell, Coquet, Bruand and McKenzie2006). Estimating soil hydraulic properties using PTFs is widely applied, but has not proved to be accurate enough on many occasions. Also, inverse modelling techniques can be employed to deduce root development and root distribution for the given soil.
FUTURE DEVELOPMENTS
The developments discussed so far will lead to improvements in water use efficiency for crop production and amenity horticulture. The pressing need is to introduce better means of adjusting irrigation for differences in soil and weather conditions. Irrigation is often applied in amounts sufficient to compensate for predicted water losses without proper consideration of soil water. Inevitably, the plants do not make full use of the water stored in the soil. Irrigation practice needs to take account of the ability of crops to sustain near maximum growth rate even when the soil water content is well below that at field capacity and also of the ability of deep-rooted crops to satisfy much of their needs for water from the subsoil. Several advances provide ways of quantitatively meeting these requirements, especially the development of soil water sensors, improved understanding of crop–soil water relationships and the development of mechanistic models for soil water dynamics. Serious consideration should be given to developing a combined strategy for using the sensor measurements and model predictions to improve irrigation practice.
Full use needs to be made of the rapid progress of wireless networking for collecting and disseminating data. Research is also required to improve soil water sensors. They need to be less expensive, to cover a wider range of soil water potentials, to facilitate improved installation so that there is more effective contact between soil and sensor, and to respond more rapidly to changes in water contents. Methods of assessing irrigation requirements should be sought that do not involve estimates of water content at field capacity, as its determination is rather subjective and inaccurate. Inexpensive but rapid means of assessing soil texture or hydraulic properties down the soil profile are required to estimate their variation across fields and to allow accurate calculations of the distribution of soil water down the soil profile from sensor measurements at specific points.
Within the foreseeable future, many irrigation systems will have soil water and temperature sensors at pre-determined positions and depths throughout the irrigation area. Data from them will be wirelessly transmitted to a base station, processed and used to adjust irrigation across the area according to need. It is also likely that the latter process will become fully automated and that all the information will be placed on the internet so that, amongst other things, a remote operator could, if the need arises, overwrite the automatic system. This will result in less waste of water and more efficient use of operator's time.
CONCLUSIONS
• High yields of many crops can be obtained even when the soil moisture content to the depth of rooting is maintained far below that at field capacity. This means that irrigation practice can be better adapted so that water loss from drainage and from evaporation from moist soil surfaces is minimized and transpiration requirements can be largely met from water stored in the subsoil. Other crops, however, are much more sensitive to water stress, and more generally there are stages of growth at which crops are particularly sensitive to such stress.
• Simulation models of varying complexity have been introduced for predicting the effects of soil water on crops and their validity tested in field experiments. The models, however, need to incorporate algorithms for classical soil water theory for improving the predictions and widening their application since the computational difficulties of doing so have now been largely overcome. They should, amongst other things, improve the estimation of irrigation requirements from soil sensor measurements of soil water down the profile.
• Spatial differences in soil hydraulic properties and thus various irrigation needs across a field mean that a uniform application of water results in some areas receiving too much water and others too little. Water can only penetrate some soils extremely slowly either because of their physical properties or because of their water repellence. Greater spatial and temporal control of irrigation may address these problems.
• Commercially available soil water sensors range from high performance expensive sensors that are required for precise monitoring in some intensive horticulture, to poorer performance sensors that are sufficiently inexpensive for large numbers to be used in monitoring soil water to depth across a substantial area.
• Sensors have been installed at a given depth throughout large glasshouses and also over urban landscapes and their outputs used to automatically control irrigation. They have also been installed at different depths in deep soils beneath field crops at representative stations throughout the irrigated area and the outputs from the sensors collected by a central PC.
• Wireless technology is greatly extending the use that can be made of soil water sensors in improving irrigation practice. Key features include nodes consisting of smart circuit boards at different positions within a field to collect local sensor data and transmit it to a central PC for processing. Installation of nodes that can ‘talk’ to one another enable low cost sensors to be distributed and collect information over a wide area and require little maintenance. Progress is being made in deducing from such sensor information how applications of water should be varied across fields and how this information can be implemented by wirelessly controlled remote equipment.
The present work was partially funded by the EU project Grant Agreement Number: 222440. The Project was funded by the Seventh Framework Programme of the European Community for research, technological development and demonstration activities (2007–2013) under the Specific Programme ‘Capacities’ (Research for the Benefit of SMEs).