



1 Introduction
Let
$M^d$
 be a d-dimensional
$C^\infty $
 compact Riemannian manifold without boundary. Denote by
$\mathfrak {X}^r(M^d)(r\geq 1)$
 the space of all
$C^r$
 vector fields on
$M^d$
 . Let
$\varphi ^X_t=(\varphi _t)_{t\in \mathbb {R}}$
 be the
$C^1$
 flow generated by a vector field
$X\in \mathfrak {X}^1(M^d)$
 , for simplicity, denoted by
$\varphi _t$
 . The derivative of the flow with respect to the space variable is called the tangent flow and is denoted by
$\Phi _t={d}\varphi ^X_t$
 . Fix a smooth Riemannian metric on
$M^d$
 . We get a scalar product in every tangent space
$T_xM^d$
 ,
$x\in M^d$
 , which depends on x in a differentiable way. The limit

is called a Lyapunov exponent for a tangent vector
$v\in T_xM^d$
 . The Lyapunov exponents of a differential equation are a natural generalization of the eigenvalues of the matrix in the linear part of the equation. Lyapunov exponents describe asymptotic evolution of a tangent map: positive or negative exponents correspond to exponential growth or decay of the norm, respectively, whereas vanishing exponents mean a lack of exponential behavior.
By the Oseledec theorem [Reference Oseledec25], the limit
$\chi (x,v)$
 exists for all non-zero vectors v based on almost all state points
$x\in M^d$
 with respect to a given invariant measure and it is independent of the points if the measure is ergodic. Precisely, let
$\mu $
 be an invariant measure of flow
$\varphi _t$
 , by the Oseledec theorem [Reference Oseledec25]. For
$\mu $
 -almost every x, there is a positive integer
$k(x)$
 , real numbers
$\chi _1(x)<\chi _2(x)<\cdots <\chi _{k(x)}(x)$
 and a measurable
$\Phi _t$
 -invariant splitting

such that

The numbers
$\chi _1(x),\ldots ,\chi _{k(x)}(x)$
 are called Lyapunov exponents at point x of
$\Phi _t$
 with respect to
$\mu $
 . Denote by

the multiplicities of those Lyapunov exponents, and the vector formed by these numbers (counted with multiplicity and listed in increasing order) is called the Lyapunov vector at point x of
$\Phi _t$
 with respect to
$\mu $
 . Regardless of the multiplicity, we rewrite the Lyapunov exponents of
$\mu $
 by
$\unicode{x3bb} _1(x)\leq \unicode{x3bb} _2(x)\leq \cdots \leq \unicode{x3bb} _d(x)$
 . It means that

If
$\mu $
 is an ergodic invariant measure, then
$k(x),\chi _1(x),\ldots ,\chi _{k(x)}(x),\unicode{x3bb} _1(x),\ldots ,\unicode{x3bb} _d(x)$
 are constants that are independent of x. The Lyapunov exponent is an active topic in the theory of non-uniformly hyperbolic systems, known as the Pesin theory, which recovers hyperbolic behavior for points whose Lyapunov exponents are all non-zero. Furthermore, these points have well-defined unstable and stable invariant manifolds. In view of these reasons, an ergodic invariant measure of a flow is called hyperbolic if its Lyapunov exponents are different from zero except in the direction of flow.
For diffeomorphisms, Anosov [Reference Anosov2] proved that a non-wandering orbit segment has a true periodic orbit nearby for the uniformly hyperbolic diffeomorphisms. For Axiom A diffeomorphisms, Sigmund [Reference Sigmund31] proved that periodic measures are dense in the set of all invariant measures. Katok [Reference Katok11] showed that hyperbolic periodic points are dense in the closure of the basin of a given hyperbolic measure for
$C^{1+\alpha }(\alpha>0)$
 diffeomorphisms. Later, Wang and Sun [Reference Wang and Sun35] enhanced Katok’s work showing that the Lyapunov exponents of an ergodic hyperbolic invariant measure for
$C^{1+\alpha }(\alpha>0)$
 diffeomorphisms are approximated by those of a hyperbolic atomic measure on a periodic orbit (see also [Reference Zhou and Sun38] for
$C^1$
 diffeomorphisms when the Oseledec splitting is dominated). For more approximation properties, see, for example, [Reference Liang, Liao and Sun16, Reference Liang, Liu and Sun17]. Since a vector field is a continuous dynamical system with respect to the time variable and a diffeomorphism can be regarded as a time-
$1$
 map of some suitable vector field, the dynamical behavior of vector field and diffeomorphism is similar in most cases. By considering the sectional Poincaré maps of the vector field, sometimes one can get some (not all) similar properties between d-dimensional vector fields and
$(d-1)$
 -dimensional diffeomorphisms. It is natural to ask the following two questions.
-
(1) Are the hyperbolic periodic points dense in the closure of the basin of a given hyperbolic invariant measure for vector fields?
-
(2) Can the Lyapunov exponents of an ergodic hyperbolic invariant measure for vector fields be approximated by those of a hyperbolic atomic measure on a periodic orbit?
For question
$(1)$
 , Ma [Reference Ma23] stated that hyperbolic periodic points are dense in the closure of the basin of a given hyperbolic measure for smooth semiflows on separable Banach spaces. Recently, Li, Liang, and Liu [Reference Li, Liang and Liu13] proved that for
$C^{1+\alpha }(\alpha>0)$
 flows, every ergodic hyperbolic invariant measure which is not supported on singularities can be approximated by periodic measures. Comparing with the diffeomorphisms, singularities of vector fields bring more difficulties. Flows with singularities have rich and complicated dynamics such as the Lorenz attractor [Reference Guckenheimer9, Reference Lorenz22]. At singularities, one can not define the linear Poincaré flow (see Definition 2.1). Hence, we lose some compact properties. This prevents one from using some techniques of diffeomorphisms for singular vector fields, such as Crovisier’s central model [Reference Crovisier5], and Pujals and Sambarino’s distortion arguments [Reference Pujals and Sambarino29]. Although the sectional Poincaré maps of the vector field can get similar properties as diffeomorphisms with lower one-dimensional, some vector fields (the famous Lorenz attractor [Reference Guckenheimer9, Reference Lorenz22]) display different dynamics. In the spirit of the Lorenz attractor, geometric Lorenz attractors [Reference Afralmovic, Bykov and Sil’nikov1, Reference Guckenheimer9, Reference Guckenheimer and Williams10] were constructed in a theoretical way. Loosely speaking, a geometric Lorenz attractor is a robust attractor and it contains a hyperbolic singularity that is accumulated by hyperbolic periodic orbits in a robust way. The return map of a geometric Lorenz attractor has some discontinuous points. This fact gives extra difficulties when one wants to generalize Mañé’s [Reference Mañé24] classical argument and Katok’s [Reference Katok11] classical result.
In this paper, we consider
$C^1$
 star vector fields on three-dimensional compact Riemannian manifold
$M^3$
 , and provide positive answers to questions
$(1)$
 and
$(2)$
 . Now, we state the main result of the present paper as the following Theorems A and B.
Theorem A. Let X be a
$C^1$
 star vector field on three-dimensional compact Riemannian manifold
$M^3$
 , and
$\mu $
 be an ergodic hyperbolic invariant measure which is not supported on singularities. Then, there is a sequence of periodic measures converging to
$\mu $
 in the weak
$^*$
 topology.
For question
$(2)$
 , no answer has been given in the literature so far. Based on Theorem A, we show in the present paper that the Lyapunov exponents of an ergodic hyperbolic invariant measure are approximated by those of hyperbolic periodic measures. Lyapunov exponents of a periodic measure concentrated on a periodic orbit with period
$\pi $
 are exactly the logarithm of the norms of eigenvalues of
$\Phi _\pi $
 . By the Poincaré recurrence theorem, there always exists a zero Lyapunov exponent for
$\Phi _t$
 along the flow direction. Thus, we only consider the Lyapunov exponents of the (scaled) linear Poincaré flow (see Definition 2.1) with respect to the ergodic hyperbolic invariant measure.
Theorem B. Let X be a
$C^1$
 star vector field on three-dimensional compact Riemannian manifold
$M^3$
 , and
$\mu $
 be an ergodic hyperbolic invariant measure, which is not supported on singularities, with Lyapunov exponents
$\unicode{x3bb} _1\leq \unicode{x3bb} _2$
 of the (scaled) linear Poincaré flow. To be precise, for every
$\varepsilon>0$
 , there is a periodic point p with Lyapunov exponents
${\unicode{x3bb} _1(p)\leq \unicode{x3bb} _2(p)}$
 such that

One of the main difficulties in proving Theorems A and B is the presence of singularities. Even if there are no singularities, we cannot directly apply the standard Pesin theory as was done by Lian and Young [Reference Lian and Young15] because the vector field is only
$C^1$
 . The main challenge is to overcome the difficulties caused by singularities and
$C^1$
 differentiability. Although the shadowing lemma for singular flows established by Liao [Reference Liao21] provides us with a method to find periodic points, we cannot estimate the Lyapunov exponents of flow with respect to periodic measures as diffeomorphisms. Our paper is organized as follows. In §2, we introduce some preliminary facts on vector field. In §3, we introduce Lyapunov metric and shadowing lemma on vector field. Theorems A and B are proved in §§4 and 5, respectively.
2 Preliminaries
2.1 Basic contents of vector fields
Let
$M^d$
 be a d-dimensional
$C^\infty $
 compact Riemannian manifold without boundary. Denote by
$\mathfrak {X}^r(M^d)(r\geq 1)$
 the space of all
$C^r$
 vector fields on
$M^d$
 . Given
$X\in \mathfrak {X}^1(M^d)$
 , a point
$x\in M^d$
 is a singularity if
$X(x)=0$
 . Denote by
$\mathrm {Sing}(X)$
 the set of all singularities. A point x is regular if
$X(x)\neq 0$
 . Let
$\varphi ^X_t=(\varphi _t)_{t\in \mathbb {R}}$
 be the
$C^r$
 flow generated by a vector field X, for simplicity, denoted by
$\varphi _t$
 . A regular point p is periodic if
$\varphi _{t_0}(p)=p$
 for some
$t_0>0$
 . A critical point is either a singularity or a periodic point. Denote the normal bundle of X by

where
$\mathcal {N}_x$
 is the orthogonal complement space of the flow direction
$X(x)$
 , that is,

For the flow
$\varphi ^X_t$
 generated by X, its derivative with respect to the space variable is called the tangent flow and is denoted by
$\Phi _t={d}\varphi ^X_t$
 .
Definition 2.1. Given
$x\in M^d\setminus \mathrm {Sing}(X),v\in \mathcal {N}_x$
 and
$t\in \mathbb {R}$
 , the linear Poincaré flow

is defined as

Namely,
$\psi _t(v)$
 is the orthogonal projection of
$\Phi _t(v)$
 on
$\mathcal {N}_{\varphi _t(x)}$
 along the flow direction
$X(\varphi _t(x))$
 .
Fix
$T>0$
 . The norm

is uniformly upper bounded on
$\mathcal {N}$
 , although
$M^d\setminus \mathrm {Sing}(X)$
 may be not compact. Denote by

the mininorm of
$\psi _T$
 . Since

the mininorm
$m(\psi _T)$
 is uniformly bounded from
$0$
 on
$\mathcal {N}$
 . Another useful flow is the scaled linear Poincaré flow
$\psi _t^*:\mathcal {N}\rightarrow \mathcal {N}$
 , which is defined as

where
$x\in M^d\setminus \mathrm {Sing}(X),v\in \mathcal {N}_x$
 and
$\langle X(x)\rangle $
 is the one-dimensional subspace of
$T_xM^d$
 generated by the flow direction
$X(x)$
 .
The linear Poincaré flow
$\psi _t$
 loses the compactness due to the existence of singularities. To overcome this difficulty, the linear Poincaré flow can also be defined in a more general way by Liao [Reference Liao18]. Li, Gan, and Wen [Reference Li, Gan and Wen12] used the terminology of ‘extended linear Poincaré flow’. For every point
$x\in M^d$
 , the sphere fiber at x is defined as

Then, the sphere bundle

is compact. For each
$v\in SM^d$
 , one can define the unit tangent flow

as

Given a compact invariant set
$\Lambda $
 of the flow
$\varphi _t$
 , denote by

in
$SM^d$
 . Thus, the essential difference between
$\widetilde {\Lambda }$
 and
$\Lambda $
 is on the singularities. We can get more information on
$\widetilde {\Lambda }$
 : it tells us how regular points in
$\Lambda $
 accumulate singularities. For every
$x\in M^d$
 , and any two orthogonal vectors
$v_1\in S_xM^d$
 ,
$v_2\in T_xM^d$
 , one can define

By the definition, the two components of
$\Theta _t$
 are still orthogonal. If we denote

then for every regular point
$x\in M^d$
 and every vector
$v\in \mathcal {N}_x$
 , one has that

By the continuity of
$\Theta _t$
 , one can extend the definition of
$\psi _t$
 to singularities: for every vector
$u\in \widetilde {\Lambda }$
 , one can define

Then,
$\widetilde {\mathcal {N}}$
 is a
$(d-1)$
 -dimensional vector bundle on the base space
$\widetilde {\Lambda }$
 . For every
$u\in \widetilde {\Lambda }$
 and every
$v\in \widetilde {\mathcal {N}}_u$
 , one can define a flow

Then, the linear Poincaré flow
$\psi _t$
 can be ‘embedded’ in the flow
$\Theta _t$
 . By the definition,
$\text {Proj}_2(\Theta _t)$
 is a continuous flow defined on
$\widetilde {\Lambda }$
 . Thus,
$\widetilde {\psi }_t(v)$
 varies continuously with respect to the vector field X, the time t, and the vector v, and can be viewed as a compactification of
$\psi _t$
 .
For every
$x\in M^d\setminus \mathrm {Sing}(X)$
 and every
$\delta>0$
 small, the normal manifold of x is defined as

where
$\mathcal {N}_x(\delta )=\{v\in \mathcal {N}_x:~\lvert v\rvert \leq \delta \}$
 . When
$\delta $
 is small enough,
$N_x(\delta )$
 is an embedded submanifold which is diffeomorphic to
$\mathcal {N}_x$
 . Furthermore,
$N_x(\delta )$
 is a local cross-section transverse to the flow. To study the dynamics in a small neighborhood of a periodic orbit of a vector field, Poincaré defined the sectional return map of a cross-section of a periodic point. By generalizing this idea to every regular point, one can define the sectional Poincaré map between any two cross-sections at any two points in the same regular orbit. For every
$T>0$
 and
$x\in M^d\setminus \mathrm {Sing}(X)$
 , the Poincaré map

is the holonomy map generated by the flow
$\varphi _t$
 , where
$\delta $
 and
$\delta '$
 depend on the choice of x and T. In addition, we call a local lift of Poincaré map
$P_{x,\varphi _T(x)}$
 in the normal bundle,

the sectional Poincaré map. Eliminating the influence of flow speed, we will also consider the scaled sectional Poincaré map
$\mathcal {P}^*_{x,\varphi _T(x)}$
 which is defined by

Moreover, we can see that

For the sectional Poincaré map, we have the following lemmas [Reference Gan and Yang8, Reference Wu, Yang and Zhang37], which explains the rationality of the definition, states the uniform continuity of the sectional Poincaré map up to flow speed, and estimates the return time.
Lemma 2.2. [Reference Gan and Yang8, Lemma 2.3]
Given
$X\in \mathfrak {X}^1(M^d)$
 and
$T>0$
 , there exists
$\beta _T>0$
 such that for every
$x\in M^d\setminus \mathrm {Sing}(X)$
 , the sectional Poincaré map

is well defined, where
$C_T=\lVert \psi _T\rVert $
 is a bounded constant.
Lemma 2.3. [Reference Gan and Yang8, Lemma 2.4]
Given
$X\in \mathfrak {X}^1(M^d)$
 and
$T>0$
 , and reducing
$\beta _T>0$
 in Lemma 2.2 if necessary, for every
$x\in M^d\setminus \mathrm {Sing}(X)$
 , for the sectional Poincaré map

$D\mathcal {P}_{x,\varphi _T(x)}$
 is uniformly continuous in the following sense: for each
$\epsilon>0$
 , there exists
${\rho \in (0,\beta _T]}$
 such that for every
$x\in M^d\setminus \mathrm {Sing}(X)$
 and
$y,~y'\in \mathcal {N}_x(\beta _T\lvert X(x)\rvert )$
 , if
$\lvert y-y'\rvert \leq \rho \lvert X(x)\rvert $
 , then

Lemma 2.4. [Reference Wu, Yang and Zhang37, Lemma 4.5]
Given
$X\in \mathfrak {X}^1(M^d)$
 , let
$\beta =\beta _1$
 and
$C_1$
 be the constants in Lemma 2.2 associated to the time-one map
$\varphi _1$
 . Then, by reducing
$\beta>0$
 if necessary, there is
$\kappa>0$
 such that for every
$x\in M^d\setminus \mathrm {Sing}(X)$
 and every
$y\in N_x(\beta \lvert X(x)\rvert )$
 , there is a unique
$t=t(y)\in (0,2)$
 satisfying that

Now, we review some definitions on various splittings of the vector field.
Definition 2.5. Let
$\Lambda $
 be an invariant set of vector field X,
$T_\Lambda M^d=E\oplus F$
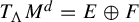 be an invariant splitting with respect to the tangent flow
$\Phi _t$
 over
$\Lambda $
 . We call the splitting
$T_\Lambda M^d=E\oplus F$
 a dominated splitting with respect to the tangent flow
$\Phi _t$
 if there are constants
$C\geq 1$
 ,
$\unicode{x3bb}>0$
 such that for every
$x\in \Lambda $
 and
$t\geq 0$
 , one has that

For simplicity, denote by
$E\prec F$
 .
Definition 2.6. Let
$\Lambda $
 be an invariant set of vector field X and
$T_\Lambda M^d=E\oplus \langle X\rangle \oplus F$
 be an invariant splitting with respect to the tangent flow
$\Phi _t$
 over
$\Lambda $
 . The splitting
${T_\Lambda M^d=E\oplus \langle X\rangle \oplus F}$
 is called a hyperbolic splitting with respect to the tangent flow
$\Phi _t$
 if there are two constants
$C\geq 1$
 and
$\unicode{x3bb}>0$
 such that

where
$\langle X\rangle $
 denotes the subspace generated by the vector field. Correspondingly, the set
$\Lambda $
 is called hyperbolic.
Note that
$\langle X(x)\rangle $
 is zero subspace
$\{0\}$
 at each singularity
$x\in M^d$
 and is a one-dimensional subspace at each regular point
$x\in M^d$
 . Since the constants C and
$\unicode{x3bb} $
 are independent of
$x\in \Lambda $
 in Definition 2.6, one can derive that, in every hyperbolic set, regular points cannot accumulate on singularities. Moreover, it is easy to prove that the hyperbolic splitting
$E(x)\oplus \langle X(x)\rangle \oplus F(x)$
 varies continuously with x and that if
$\Lambda $
 is hyperbolic, so is the closure
$\overline {\Lambda }$
 .
Remark. Since linear Poincaré flow
$\psi _t$
 , scaled linear Poincaré flow
$\psi ^*_t$
 , and extended linear Poincaré flow
$\widetilde {\psi }_t$
 are induced by tangent flow
$\Phi _t$
 , we can define the corresponding dominated (hyperbolic) splitting with respect to
$\psi _t$
 ,
$\psi ^*_t$
 , and
$\widetilde {\psi }_t$
 . For example, let
$\Lambda $
 be an (not necessarily compact) invariant set of flow
$\varphi _t$
 . An invariant splitting
$\mathcal {N}_\Lambda =E\oplus F$
 over the invariant set
$\Lambda $
 is called dominated (hyperbolic) splitting with respect to the linear Poincaré flow
$\psi _t$
 if there are constants
$C\geq 1$
 ,
$\unicode{x3bb}>0$
 such that for every
$x\in \Lambda $
 and
$t\geq 0$
 , one has that

Furthermore,
$\mathcal {N}_\Lambda =E\oplus F$
 is a dominated (hyperbolic) splitting with respect to
$\psi _t$
 if and only if it is a dominated (hyperbolic) splitting with respect to
$\psi ^*_t$
 (
$\widetilde {\psi }_t$
 ).
The notion of star system came from the study of the famous stability conjecture. Recall that a classical theorem of Smale [Reference Smale33] (for diffeomorphisms) and Pugh and Shub [Reference Pugh and Shub28] (for flows) states that Axiom A plus the no-cycle condition implies the
$\Omega $
 -stability. Palis and Smale [Reference Palis and Smale26] conjectured that the converse also holds, which has been known as the
$\Omega $
 -stability conjecture. In the study of the conjecture, Pliss, Liao, and Mañé noticed an important condition called (by Liao) the star condition. Indeed, the
$\Omega $
 -stability implies the star condition easily (Franks [Reference Franks7] and Liao [Reference Liao19]). Thus, whether the star condition can give back Axiom A plus the no-cycle condition became a striking problem, raised by Liao [Reference Liao20] and Mañé [Reference Mañé24]. Especially, for flows, there are counterexamples if the flow has a singularity. For instance, the geometric Lorenz attractor [Reference Guckenheimer9], which has a singularity, is a star flow but fails to satisfy Axiom A.
Definition 2.7. A vector field
$X\in \mathfrak {X}^1(M^d)$
 is called a star vector field if there is a
$C^1$
 neighborhood
$\mathcal {U}$
 of X such that for every
$Y\in \mathcal {U}$
 , all singularities and all periodic orbits of
$\varphi ^Y_t$
 are hyperbolic.
The set of all star vector fields on
$M^d$
 is denoted by
$\mathfrak {X}^*(M^d)$
 which is endowed with
$C^1$
 -topology.
2.2 Lyapunov exponents of vector fields
In this section, we introduce some ergodic theory for a vector field. Given a vector field
$X\in \mathfrak {X}^r(M^d)(r\geq 1)$
 , a measure
$\mu $
 is called invariant with respect to the flow
$\varphi ^X_t$
 (a vector field X) if
$\mu $
 is an invariant measure of
$\varphi _T$
 for every
$T\in \mathbb {R}$
 . Similarly, a measure
$\mu $
 is called ergodic with respect to the flow
$\varphi ^X_t$
 (a vector field X) if
$\mu $
 is an ergodic invariant measure of
$\varphi _T$
 for every
$T\in \mathbb {R}$
 . The set of all invariant measures and all ergodic measures of the vector field are denoted by
$\mathcal {M}(X)$
 ,
$\mathcal {E}(X)$
 , respectively. Let
$\mu $
 be an invariant measure of flow
$\varphi _t$
 . By the Oseledec theorem [Reference Oseledec25], for
$\mu $
 -almost every x, there is a positive integer
$k(x)\in [1,d]$
 , real numbers
${\chi _1(x)<\chi _2(x)<\cdots <\chi _{k(x)}(x)}$
 , and a measurable
$\Phi _t$
 -invariant splitting

such that

The numbers
$\chi _1(x),\ldots ,\chi _{k(x)}(x)$
 are called Lyapunov exponents at point x of
$\Phi _t$
 with respect to
$\mu $
 and the vector formed by these numbers (counted with multiplicity and listed in increasing order) is called the Lyapunov vector at point x of
$\Phi _t$
 with respect to
$\mu $
 . The index of
$\mu $
 , denoted by
$\text {Ind}(\mu )$
 , is defined as

If
$\mu $
 is an ergodic invariant measure, then these numbers
$k(x),\chi _1(x),\ldots ,\chi _{k(x)}(x)$
 are constants. By the Poincaré recurrence theorem, for
$\mu $
 -almost every
$x\in M^d$
 , one has that

where
$\langle X(x)\rangle $
 is the one-dimensional subspace of
$T_xM^d$
 generated by the flow direction
$X(x)$
 . Thus, it follows that there always exists one zero Lyapunov exponent for
$\Phi _t$
 along the flow direction.
For an ergodic invariant measure
$\mu $
 which is not concentrated on
$\mathrm {Sing}(X)$
 , according to the definition of linear Poincaré flow
$\psi _t:\mathcal {N}\rightarrow \mathcal {N}$
 and the Oseledec theorem [Reference Oseledec25], for
$\mu $
 -almost every x, there is a positive integer
$k\in [1,d-1]$
 , real numbers
$\chi _1<\chi _2<\cdots <\chi _k$
 , and a measurable
$\psi _t$
 -invariant splitting (for simplicity, we omit the base point)

on a normal bundle such that

Accordingly, the numbers
$\chi _1,\ldots ,\unicode{x3bb} _k$
 are called Lyapunov exponents of
$\psi _t$
 with respect to the ergodic measure
$\mu $
 and the vector formed by these numbers (counted with multiplicity and listed in increasing order) is called the Lyapunov vector of
$\psi _t$
 with respect to
$\mu $
 . According to the definition of the scaled linear Poincaré flow
$\psi _t^*:\mathcal {N}\rightarrow \mathcal {N}$
 , we have that

Since the Lyapunov exponent for
$\Phi _t$
 along the flow direction is zero, namely,

one has that

Thus, for
$\mu $
 -almost every x, we also have a positive integer
$k\in [1,d-1]$
 , real numbers
$\chi _1<\chi _2<\cdots <\chi _k$
 , and a measurable
$\psi ^*_t$
 -invariant splitting (for simplicity, we omit the base point)

on a normal bundle satisfying that

Then, the numbers
$\chi _1,\ldots ,\chi _k$
 are called Lyapunov exponents of
$\psi ^*_t$
 with respect to the ergodic measure
$\mu $
 and the vector formed by these numbers (counted with multiplicity and listed in increasing order) is called the Lyapunov vector of
$\psi ^*_t$
 with respect to
$\mu $
 . It means that the Lyapunov exponents of the scaled linear Poincaré flow and those of the linear Poincaré flow are the same. Hence, the scaled linear Poincaré flow and the linear Poincaré flow also have the same Oseledec splitting.
Given a periodic point z (period
$\pi (z)$
 ) of vector field X, we can define the Borel probability invariant measure

supported on the periodic orbit of z, where
$\delta _y$
 denotes the Dirac measure supported on y. By the Oseledec theorem, we also have corresponding Lyapunov exponents and Lyapunov vector with respect to the invariant measure
$\mu _z$
 .
Definition 2.8. An ergodic measure
$\mu $
 of the flow
$\varphi _t$
 is regular if it is not supported on a singularity. An ergodic regular measure is hyperbolic if the Lyapunov exponents of the linear Poincaré flow
$\psi _t$
 are all non-zero.
Remark. We can also define the hyperbolicity of an ergodic measure by using the tangent flow
$\Phi _t=\mathrm {d}\varphi _t$
 as usual. However, for ergodic measures that are not supported on singularities, there will be one zero Lyapunov exponent for the tangent flow along the flow direction.
Given an ergodic hyperbolic invariant measure
$\mu $
 , let
$\Gamma $
 (called the Oseledec’s basin of
$\mu $
 in [Reference Wang, Cao and Zou34]) be the set of all points that are regular with respect to linear Poincaré
$\psi _t$
 in the sense of Oseledec [Reference Oseledec25]. For
$x\in \Gamma $
 , let

be the decomposition of normal bundle corresponding to the distinct Lyapunov exponents

with multiplicities
$d_1,d_2,\ldots ,d_k\geq 1$
 . Then, dim
$(E_i(x))=d_i$
 for
$i=1,2,\ldots ,k$
 . Denote

We call the splitting

hyperbolic Oseledec splitting. Correspondingly, we call
$E^s$
 and
$E^u$
 a stable bundle and unstable bundle.
The support set of a measure
$\mu $
 is defined as

For star vector, it is proved in [Reference Shi, Gan and Wen30] that every ergodic measure of a star vector field
${X\in \mathfrak {X}^*(M^d)}$
 is hyperbolic. Li et al [Reference Li, Shi, Wang and Wang14] assert (in the following Lemma 2.9) the existence of dominated splitting on
$\mathcal {N}_{\text {supp}(\mu )\backslash \text {Sing}(X)}$
 for each ergodic measure
$\mu $
 of a star vector field with respect to the scaled linear Poincaré flow.
Lemma 2.9. [Reference Li, Shi, Wang and Wang14, Lemma 2.6]
If
$\mu $
 is a non-trivial ergodic measure of a star vector field
$X\in \mathfrak {X}^*(M)$
 , then there is a dominated splitting
$\mathcal {N}_{\text {supp}(\mu )\backslash \text {Sing}(X)}=E\oplus F$
 with respect to the scaled linear Poincaré flow
$\psi ^*_t$
 such that

3 Lyapunov norms and shadowing lemma
3.1 Lyapunov norms and Lyapunov charts
In this section, we only consider a
$C^1$
 vector field
$X\in \mathfrak {X}^1(M^d)$
 . Since we cannot define the linear Poincaré flow (see Definition 2.1) at singularities, we lose some uniformity. Fortunately for us, we may still regain some uniform properties when we consider the scaled linear Poincaré flow.
On the tangent space
$TM^d$
 , the Sasaki metric (see [Reference Burns, Masur and Wilkinson4, §2.1]), denote by
$d_{S}$
 a useful metric which is introduced by the Riemannian metric on
$M^d$
 . By the compactness of
$M^d$
 , there is a small constant
$\rho _S$
 such that for every
$x,~y\in M^d$
 with
$d(x,y)<\rho _S$
 , there is a unique geodesic joining y to x. Furthermore, if
$u_x\in T_xM^d$
 and
$u_y\in T_yM^d$
 with
$d_{S}(u_x,u_y)\leq \rho _S$
 or
$\lvert u_x-u^{\prime }_y\rvert \leq \rho _S$
 , where
$u^{\prime }_y\in T_xM^d$
 is obtained by parallel transporting
$u_y$
 along the geodesic from y to x, then

Moreover, there is a real number
$K_{G^1}$
 such that for any two unit vectors
$u_1,~u_2\in TM^d$
 , one has that

where
$d_{G^1}$
 is the Grassmann distance on the one-dimensional Grassmann bundle over
$M^d$
 , that is,

Since
$M^d$
 is compact, there is a constant
$K_0$
 such that

Li, Liang, and Liu [Reference Li, Liang and Liu13] pointed out the relationship between the Sasaki metric and the Riemannian metric as the following lemma.
Lemma 3.1. [Reference Li, Liang and Liu13, Lemma 3.1]
There are constants
$K_1>K_0$
 and
$\beta ^*_0>0$
 such that for every
$x\in M^d\backslash \text {Sing}(X)$
 and each
$y\in B(x,\beta ^*_0\lvert X(x)\rvert )$
 , one has that:
-
(1) $1-K_1\cdot {d(x,y)}/{\lvert X(x)\rvert }\leq {\lvert X(x)\rvert }/{\lvert X(y)\rvert }\leq 1+K_1\cdot {d(x,y)}/{\lvert X(x)\rvert }$
 ;
-
(2) $d_S({X(x)}/{\lvert X(x)\rvert }, {X(y)}/{\lvert X(y)\rvert })\leq K_1\cdot {d(x,y)}/{\lvert X(x)\rvert }$
; -
(3) $d_{G^1}(\langle X(x)\rangle ,\langle X(y)\rangle )\leq K_1\cdot {d(x,y)}/{\lvert X(x)\rvert }$
.


Let
$r_0$
 be the radius such that the exponential map is a
$C^{\infty }$
 diffeomorphism in
$T_xM^d(r_0)$
 . Reducing
$\beta ^*_0>0$
 if necessary, we may assume that

Thus, Lemma 3.1(1) means that there is no singularity in
$B(x,\beta ^*_0\lvert X(x)\rvert )$
 . Next, we analyze the sectional Poincaré flow in local charts of scaled neighborhoods, the so-called Liao scaled charts, to obtain some uniformity. One can see similar discussions in [Reference Crovisier and Yang6, Reference Gan and Yang8, Reference Wen and Wen36].
Let
$\{e_1,\ldots ,e_d\}$
 be an orthonormal basis of
$\mathbb {R}^d$
 . For every
$x\in M^d$
 , take an orthonormal basis
$\{e^x_1,\ldots ,e^x_d\}$
 of
$T_xM^d$
 . We can get a linear isometry

which is a metric change of coordinates from Euclidean space to tangent space, such that

Then,

where
$\langle \cdot ,\cdot \rangle $
 is the standard scalar product on
$\mathbb {R}^d$
 . Denote by

Then,
$\mathrm {Exp}_x|_{\mathbb {R}^d(r_0)}$
 is a
$C^{\infty }$
 diffeomorphism from
$\mathbb {R}^d(r_0)$
 to
$B(x,r_0)$
 for every
$x\in M^d$
 . The flow in the neighborhood
$B(x,r_0)$
 can be locally lifted to
$\mathbb {R}^d(r_0)$
 by
$\mathrm {Exp}_x$
 . Namely, if there exists a point
$p\in \mathbb {R}^d$
 and
$t_1<0<t_2$
 such that

then we can define a flow

In this Liao scaled chart of x, the flow
$\varphi ^X_t$
 generated by the vector field X satisfies the differential equation

where
$\widehat {X}_x(z)=D(\mathrm {Exp}_x|_{\mathbb {R}^d(r_0)})^{-1}\circ X\circ \mathrm {Exp}_x(z)$
 and
$\mathrm {Exp}_x(0)=x$
 ,
$\lvert \widehat {X}_x(0)\rvert =\lvert X(x)\rvert $
 . Since
$M^d$
 is compact, there is a constant
$K_{\mathrm {E}}>1$
 such that

Thus, increasing
$K_0$
 if necessary, we may also assume that

Therefore,

For every regular point
$x\in M^d$
 , take
$e^x_1= {X(x)}/{\lvert X(x)\rvert }$
 . Then,
$\widehat {X}_x(0)= (\lvert X(x)\rvert ,0,0,\ldots ,0)$
 . Given
$x\in M^d\backslash \mathrm {Sing}(X)$
 , for every
$y\in B(x,\beta ^*_0\lvert X(x)\rvert )$
 , we may choose an orthonormal basis
$\{e^y_1,\ldots ,e^y_d\}$
 of
$T_yM^d$
 such that
$e^y_1= {X(y)}/{\lvert X(y)\rvert }$
 and

Under this orthonormal bases in
$T_{B(x,\beta ^*_0\lvert X(x)\rvert )}M^d$
 , we can get a uniform estimate on the
$C^1$
 norm of the diffeomorphism
$\mathrm {Exp}_x$
 as the following lemma.
Lemma 3.2. [Reference Li, Liang and Liu13, Lemma 3.2]
There is
$K_2>1$
 such that for every
$x\in M^d\backslash \mathrm {Sing}(X)$
 , one has that

for every
$y_1,~y_2\in B(x,\beta ^*_0\lvert X(x)\rvert )$
 , where
$\lVert \cdot \rVert $
 is the
$C^1$
 norm.
3.2 Shadowing lemma
The concept of shadowing first appeared in a paper [Reference Sinaĭ32] by Sinaĭ where it is shown that Anosov diffeomorphisms have shadowing and furthermore that every pseudo-orbit has a unique point shadowing it. Shadowing describes the phenomenon where a true orbit of a dynamical system lies uniformly close to a pseudo-orbit. The shadowing lemma for diffeomorphisms has been described perfectly. However, for flows, the shadowing lemma is rather more complicated than that for diffeomorphisms.
Definition 3.3. Let
$\Lambda $
 be an invariant set and
$E\subset \mathcal {N}_{\Lambda \backslash \text {Sing}(X)}$
 an invariant subbundle of the scaled linear Poincaré flow
$\psi ^*_t$
 . For
$C>0$
 ,
$\eta>0$
 and
$T>0$
 ,
$x\in \Lambda \backslash \text {Sing}(X)$
 is called
$(C,\eta ,T,E)$
 -
$\psi ^*_t$
 -contracting if there exists a time partition:
$0=t_0<t_1<\cdots <t_n<\cdots $
 such that
$t_{i+1}-t_i\leq T$
 for each
$i\in \mathbb {N}$
 , and
$t_n\rightarrow \infty $
 as
$n\rightarrow \infty $
 , and

A point
$x\in \Lambda \backslash \text {Sing}(X)$
 is called
$(C,\eta ,T,E)$
 -
$\psi ^*_t$
 -expanding if it is
$(C,\eta ,T,E)$
 -
$\psi ^*_t$
 -contracting for the vector field
$-X$
 .
Definition 3.4. Given
$\eta>0$
 ,
$T>0$
 . For every
$x\in M^d\backslash \text {Sing}(X)$
 ,
$T_0>T$
 , the orbit arc
$\varphi _{[0,T_0]}(x)$
 is called
$(\eta ,T)$
 -
$\psi ^*_t$
 -quasi-hyperbolic with respect to a direct sum splitting
${\mathcal {N}_x=E(x)\oplus F(y)}$
 if there is a time partition:

such that for
$n=0,1,\ldots ,k-1$
 , one has that


The following shadowing lemma for singular flows was given by Liao [Reference Liao21].
Theorem 3.5. Let
$X\in \mathfrak {X}^1(M^d)$
 ,
$\Lambda \subset M^d\backslash \text {Sing}(X)$
 be an invariant set with a dominated splitting
$\mathcal {N}_\Lambda =E\oplus F$
 and
$\eta>0,~T>0$
 . For
$\alpha>0$
 and
$\varepsilon>0$
 , there is a number
$\delta>0$
 such that for every
$(\eta ,T)$
 -
$\psi ^*_t$
 -quasi-hyperbolic orbit segment
$\varphi _{[0,T_0]}(x)$
 satisfying
$d(x,\text {Sing}(X))>\alpha $
 and
$d(\varphi _{T_0}(x),\text {Sing}(X))>\alpha $
 and
$x\in \Lambda $
 ,
$\varphi _{T_0}(x)\in \Lambda $
 and
$d(x,\varphi _{T_0}(x))<\delta $
 , there exists a
$C^1$
 strictly increasing function
$\theta :[0,T_0]\rightarrow \mathbb {R}$
 and a periodic point
$p\in M^d$
 such that:
-
(1) $\theta (0)=0$
and
$1-\varepsilon <\theta '(t)<1+\varepsilon $
for every
$t\in [0,T_0]$
; -
(2) p is periodic with period $\theta (T_0)$
:
$\varphi _{\theta (T_0)}(p)=p$
; -
(3) $d(\varphi _t(x),\varphi _{\theta (t)}(p))<\varepsilon \lvert X(\varphi _t(x))\rvert $
for every
$t\in [0,T_0]$
.


4 Density of periodic measures: proof of Theorem A
In this section, we give the proof of Theorem A. Before proving Theorem A, we give a discussion about the Oseledec splitting. Let
$\mu $
 be an ergodic hyperbolic invariant measure of the flow
$\varphi _t$
 generated by a
$C^1$
 vector field
$X\in \mathfrak {X}^1(M^3)$
 on three-dimensional manifolds and
$\unicode{x3bb} _1\leq \unicode{x3bb} _2$
 be the Lyapunov exponents of
$\psi ^*_t$
 with respect to the ergodic hyperbolic invariant measure
$\mu $
 . Then, there is a measurable
$\psi ^*_t$
 -invariant splitting

of normal bundle on
$\Gamma $
 (Oseledec’s basin of
$\mu $
 ) satisfying that

Lemma 4.1. If the Oseledec splitting

of an ergodic hyperbolic invariant measure
$\mu $
 with respect to the three-dimensional flow
$\varphi _t$
 is a dominated splitting, then for every
$0<\epsilon \ll \min \{\lvert \unicode{x3bb} _1\rvert ,\lvert \unicode{x3bb} _2\rvert \}$
 and every
$\delta \in (0,1)$
 , there is a positive number
$L=L(\epsilon ,\delta )$
 such that:
-
• for every $T\geq L$
, there exists a measurable set
$\Gamma ^T=\Gamma ^T(\epsilon ,\delta )\subset \Gamma $
with
$\mu (\Gamma ^T)\geq 1-\delta $
; -
• there is a natural number $N=N(T)$
such that for every
$n\geq N$
and every
$x\in \Gamma ^T$
, we have that $$ \begin{align*} e^{(\unicode{x3bb}_j-\epsilon)nT}\leq\prod_{i=0}^{n-1}m(\psi^*_T|_{E_j(\varphi_{iT}(x))})\leq\prod_{i=0}^{n-1}\lVert\psi^*_T|_{E_j(\varphi_{iT}(x))}\rVert\leq e^{(\unicode{x3bb}_j+\epsilon)nT},\quad j=1,2. \end{align*} $$


Proof. According to the Oseledec theorem, for every
$x\in \Gamma $
 , we have that

Now, for every
$0<\epsilon \ll \min \{\lvert \unicode{x3bb} _1\rvert ,\lvert \unicode{x3bb} _2\rvert \}$
 and every
$\delta \in (0,1)$
 , we complete the proof of the lemma. By equation
$(*)$
 , for each
$j=1,2$
 , we have that

Therefore,

Thus, there exists a positive number
$L^+_j$
 such that for every
$T\geq L^+_j$
 , we have that

In addition, there also exists a positive number
$L^-_j$
 such that for every
$T\geq L^-_j$
 , we have that

Since Oseledec splitting

is a dominated splitting, Oseledec splitting is a continuous splitting [Reference Bonatti, Díaz and Viana3]. Therefore, for fixed
$j\in \{1,2\}$
 and every natural number
$T\geq \max \{L^+_j,~L^-_j\} $
 , the two functions

are continuous on
$\Gamma $
 .
However,
$\mu $
 is an invariant measure of
$\varphi _T$
 . By Birkhoff ergodic theorem, there exist two measurable functions
$g_{j,T}$
 and
$\widetilde {g}_{j,T}$
 such that for
$\mu $
 -almost every
$x\in M^3$
 , we have that


and


Set

By inequalities
$(**)$
 and
$(***)$
 , we have that

and

for every
$x\in \Gamma ^-_{j,T}\cap \Gamma ^-_{j,T}$
 . Namely, for every
$x\in \Gamma ^+_{j,T}\cap \Gamma ^-_{j,T}$
 , there exists
$N_j(x)$
 such that

Set

For every
$T\geq L$
 , define

Then,
$\Lambda ^T\subset \Gamma $
 and

Therefore, for every
$x\in \Lambda ^T$
 , there exists a positive integer
$N(x)=\max \{N_1(x),~N_2(x)\}$
 such that for every
$j\in \{1,2\}$
 , one has that

For
$x\in \Lambda ^T$
 , let

Denote by

Then,
$\Lambda ^T_n\subset \Lambda ^T_{n+1}$
 and

Consequently, there is
$n_0$
 satisfying
$\mu (\Lambda ^T_{n_0})>1-\delta $
 . For proving this lemma, we set

Proof of Theorem A.
Let
$\mu $
 be an ergodic hyperbolic invariant measure of the flow
$\varphi _t$
 generated by the star vector field
$X\in \mathfrak {X}^*(M^3)$
 on three-dimensional manifolds and
$\unicode{x3bb} _1\leq \unicode{x3bb} _2$
 be the Lyapunov exponents of
$\psi ^*_t$
 with respect to the ergodic hyperbolic invariant measure
$\mu $
 . Then, there is a measurable
$\psi ^*_t$
 -invariant splitting

of normal bundle on
$\Gamma $
 (Oseledec’s basin of
$\mu $
 ) satisfying that

By Lemma 2.9, there is a dominated splitting
$\mathcal {N}_\Gamma =\widetilde {E_1}\oplus \widetilde {E_2}$
 with respect to the scaled linear Poincaré flow
$\psi ^*_t$
 such that

Regarding the Lyapunov exponents, we discuss it in two cases.
Case (1). If
$\unicode{x3bb} _1$
 and
$\unicode{x3bb} _2$
 are both negative (or positive), then
$\mathrm {Ind}(\mu )=2$
 (or
$0$
 ). Therefore,

Thus,
$\mu $
 is an ergodic measure supported on an attracting (a repelling) periodic orbit.
Case (2). If
$\unicode{x3bb} _1<0<\unicode{x3bb} _2$
 , then we claim that
$\mathcal {N}_\Gamma =E_1\oplus E_2$
 is a dominated splitting.
Claim. The Oseledec splitting
$\mathcal {N}_\Gamma =E_1\oplus E_2$
 is a dominated splitting.
Proof of the Claim.
Since
$\mathcal {N}_\Gamma =\widetilde {E_1}\oplus \widetilde {E_2}$
 is a dominated splitting with respect to the scaled linear Poincaré flow
$\psi ^*_t$
 such that
$\mathrm {dim}(\widetilde {E_1})=\mathrm {Ind}(\mu )=1$
 , we only need to show that the two splittings
$\mathcal {N}_\Gamma =E_1\oplus E_2$
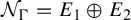 and
$\mathcal {N}_\Gamma =\widetilde {E_1}\oplus \widetilde {E_2}$
 coincide.
Given
$x\in \Gamma $
 , for the splitting
$\mathcal {N}_x=E_1(x)\oplus E_2(x)$
 , fix
$\epsilon \in (0,{(\min \{\lvert \unicode{x3bb} _1\rvert ,~\unicode{x3bb} _2\})}/{8})$
 small. There is a natural number
$T_0>0$
 such that for every
$t\geq T_0$
 , one has that

and

For the splitting
$\mathcal {N}_x=\widetilde {E_1}(x)\oplus \widetilde {E_2}(x)$
 , by the definition of dominated splitting, there are two constants
$C\geq 1$
 ,
$\unicode{x3bb}>0$
 such that for every
$t\geq 0$
 , one has that

Conversely, suppose that
$E_1(x)\nsubseteq \widetilde {E_1}(x)$
 . Then, there is a non-zero vector
${u\in \widetilde {E_1}(x)\backslash E_1(x)}$
 . However, since
$\mathrm {dim}(E_1(x))=1\leq \mathrm {dim}(\widetilde {E_1}(x))$
 ,
$\widetilde {E_1}(x)\nsubseteq E_1(x)$
 . Thus, there is a non-zero vector
$v\in E_1(x)\backslash \widetilde {E_1}(x)$
 . Therefore, there is a vector decomposition

of u under the splitting
$\mathcal {N}_x=E_1(x)\oplus E_2(x)$
 . Similarly, there is a vector decomposition

of v under the splitting
$\mathcal {N}_x=\widetilde {E_1}(x)\oplus \widetilde {E_2}(x)$
 . Thus,

and

This leads to a contradiction. Therefore, our assumption that
$E_1(x)\nsubseteq \widetilde {E_1}(x)$
 is not valid. It means that
$E_1(x)=\widetilde {E_1}(x)$
 . Thus, the two splittings
$\mathcal {N}_\Gamma =E_1\oplus E_2$
 and
$\mathcal {N}_\Gamma =\widetilde {E_1}\oplus \widetilde {E_2}$
 coincide. This completes the proof of the claim.
Let
$C(M^3)$
 be the set of all continuous functions on the manifold
$M^3$
 and
$\{f_i\}_{i=1}^{+\infty }$
 be a countable dense subset of
$C(M^3)$
 . For any two measures
$\mu ,~\nu \in \mathcal {M}(X)$
 , define

Thus,
$d_{\mathcal {M}}(\cdot ,\cdot )$
 is a metric which induces the weak
$^*$
 topology in the set
$\mathcal {M}(X)$
 . Given an ergodic hyperbolic invariant regular measure
$\mu $
 , for every
$\varepsilon>0$
 , we prove that there exists a periodic measure
$\mu _p$
 such that

First, choose n large enough such that for every invariant measure
$\nu $
 , one has that

According to the Birkhoff ergodic theorem, there is a full
$\mu $
 -measure
$\varphi $
 -invariant set
$\Lambda _B$
 such that for every
$x\in \Lambda _B$
 and every
$f\in C(M^3)$
 , one has that

Thus, there exists
$T_1>1$
 such that for every
$i=1,2,\ldots ,n$
 , every
$x\in \Lambda _B$
 , and every
$T>T_1$
 , one has that

By the claim, the hyperbolic Oseledec splitting
$\mathcal {N}_\Gamma =E_1\oplus E_2$
 is a dominated splitting. Let

then by Lemma 4.1, for every
$0<\epsilon \ll \chi $
 and every
$\delta \in (0,1)$
 , there is a positive number
$L=L(\epsilon /2,\delta )$
 such that:
-
• for every $T_0\geq L$
, there exists a measurable set
$\Gamma ^{T_0}=\Gamma ^{T_0}(\epsilon /2,\delta )\subset \Gamma $
with
$\mu (\Gamma ^{T_0})\geq 1-\delta $
; -
• there is a natural number $N=N(T_0)$
such that for every
$J\geq N$
and every
$x\in \Gamma ^{T_0}$
, we have that $$ \begin{align*} \prod_{i=0}^{J-1}\lVert\psi^*_{T_0}|_{E_1(\varphi_{iT_0}(x))}\rVert\leq e^{-(\chi-\epsilon/2)JT_0},~\prod_{i=0}^{J-1}m(\psi^*_{T_0}|_{E_2(\varphi_{iT_0}(x))})\geq e^{(\chi-\epsilon/2)JT_0}, \end{align*} $$
$$ \begin{align*} \dfrac{\lVert\psi^*_{T_0}|_{E_1(x)}\rVert}{m(\psi^*_{T_0}|_{E_2(x)})}\leq e^{-T_0(\chi-\epsilon/2)}. \end{align*} $$


Fix an integer
$T_0\geq \max \{T_1,~ L(\epsilon /2,\delta )\}$
 and let
$\eta _0=(\chi -\epsilon /2)T_0$
 . For
$k\in \mathbb {N}^+$
 , we can define the Pesin block
$\Lambda ^{T_0}_{\eta _0}(k)$
 as

According to [Reference Wu, Yang and Zhang37, Proposition 5.3],
$\Lambda ^{T_0}_{\eta _0}(k)$
 is a compact set and

Denote

Take
$\gamma>0$
 small enough. We may assume that

Recall that
$\lvert X(x)\rvert \leq K_0$
 for every
$x\in M^3$
 . Since
$f_i$
 (
$1\leq i\leq n$
 ) is uniformly continuous on
$M^3$
 , there exists
$\xi \in [0,\gamma ]$
 small enough such that for every integer
$i\in [1,n]$
 and any two points
$x,y\in M^3$
 with
$d(x,y)\leq \xi K_0$
 , we have that

Fix k large enough such that
$\mu (\Lambda ^{T_0}_{\eta _0}(k))$
 is sufficiently close to
$1$
 . For this fixed k, there is
$j=j(k)\in \mathbb {N}^+$
 such that
$k<e^{{jT_0\epsilon }/{2}}$
 . Thus, for every
$x\in \Lambda ^{T_0}_{\eta _0}(k)$
 , one has that

Set
$\eta =(\chi -\epsilon )jT_0$
 ,
$T=jT_0$
 . We consider the set

Take a point
$x_0\in \Lambda ^T_\eta (k)\cap \text {supp}(\mu )$
 . By the continuity of
$X(x)$
 , there is
$r>0$
 small enough such that for every
$x\in B(x_0,r)$
 , we have that

For
$\varepsilon '=\min \{\varepsilon ,~\xi \}>0$
 and every
$\alpha \in (0,1/k)$
 , we have a number
$\delta _0>0$
 by Theorem 3.5. Since
$\mu (B(x_0,r)\cap \Lambda ^T_\eta (k)\cap \Lambda _B)>0$
 , by the Poincaré recurrence theorem, there is a point
$y\in B(x_0,r)\cap \Lambda ^T_\eta (k)\cap \Lambda _B$
 and an integer l such that
$\varphi _{lT}(y)\in B(x_0,r)\cap \Lambda ^T_\eta (k)\cap \Lambda _B$
 with
$d(y,\varphi _{lT}(y))<\delta _0$
 . Thus, we get an
$(\eta ,T)$
 -
$\psi ^*_t$
 -quasi-hyperbolic orbit segment
$\varphi _{[0,lT]}(y)$
 satisfying:
-
• $d(y,\text {Sing}(X))>\alpha $
and
$d(\varphi _{lT}(y),\text {Sing}(X))>\alpha $
; -
• $y\in \Lambda ^T_\eta (k)$
,
$\varphi _{lT}(y)\in \Lambda ^T_\eta (k)$
and
$d(y,\varphi _{lT}(y))<\delta _0$
.


By Theorem 3.5, there exists a strictly increasing
$C^1$
 function
$\theta :[0,lT]\rightarrow \mathbb {R}$
 and a periodic point
$p\in M^3$
 such that:
-
(1) $\theta (0)=0$
and
$1-\gamma \leq 1-\xi <1-\varepsilon '<\theta '(t)<1+\varepsilon '<1+\xi \leq 1+\gamma $
for every
$t\in [0,lT]$
; -
(2) p is periodic with period $\theta (lT)$
:
$\varphi _{\theta (lT)}(p)=p$
; -
(3) $d(\varphi _t(y),\varphi _{\theta (t)}(p))<\varepsilon '\lvert X(\varphi _t(x))\rvert <\xi \lvert X(\varphi _t(x))\rvert $
for every
$t\in [0,lT]$
.


Therefore, for every
$i=1,2,\ldots ,n$
 , we have that

and

Thus,

Denote by
$\mu _p$
 the invariant measure on the periodic orbit
$\mathrm {Orb}(p)$
 . From equations
$(\ddagger )$
 and
$(\ddagger \ddagger )$
 , we have that

This completes the proof of Theorem A.
5 Approximation of Lyapunov exponents: proof of Theorem B
In this section, we give the proof of Theorem B. Let
$\varphi _t$
 be the
$C^1$
 flow generated by a star vector field
$X\in \mathfrak {X}^*(M^3)$
 on three-dimensional manifolds and
$\mu $
 be an ergodic hyperbolic invariant measure of
$\varphi _t$
 which is not supported on singularities. By Lemma 2.9, every star vector field admits a dominated splitting
$\mathcal {N}_{\text {supp}(\mu )\backslash \text {Sing}(X)}=E\oplus F$
 with respect to the scaled linear Poincaré flow
$\psi ^*_t$
 such that
$\mathrm {dim}(E)=\mathrm {Ind}(\mu )$
 . According to the similar discussions on Lyapunov exponents as two different cases in the proof of Theorem A, we only need to consider the case where one Lyapunov exponent is positive and the other is negative. Namely, the Oseledec splitting
$\mathcal {N}_\Gamma =E_1\oplus E_2$
 of the ergodic hyperbolic invariant measure
$\mu $
 is a dominated splitting and we have that

where
$\unicode{x3bb} _1<0<\unicode{x3bb} _2$
 . To complete the proof of Theorem B, we present two propositions as Propositions 5.1 and 5.2.
Proposition 5.1. (The approximation of largest Lyapunov exponent)
Let
$\mu $
 be an ergodic hyperbolic invariant regular measure of the
$C^1$
 star vector field
$X\in \mathfrak {X}^1(M^3)$
 on a compact three-dimensional smooth Riemannian manifold and
$\unicode{x3bb} _1<\unicode{x3bb} _2$
 be the Lyapunov exponents of
$\mu $
 with respect to the scaled linear Poincaré flow
$\psi ^*_t$
 . For every
$\epsilon>0$
 , there is a hyperbolic periodic point p of
$\varphi _t$
 such that

where
$\unicode{x3bb} _1(p)\leq \unicode{x3bb} _2(p)$
 are the Lyapunov exponents of the periodic measure
$\mu _p$
 with respect to the scaled linear Poincaré flow
$\psi ^*_t$
 .
Proof. Let

Since the Oseledec splitting
$\mathcal {N}_\Gamma =E_1\oplus E_2$
 is a dominated splitting, by Lemma 4.1, for every
$0<\epsilon /4\ll \chi $
 and every
$\delta _1\in (0,1/9)$
 , there is a positive number
$L=L(\epsilon /4,\delta _1)$
 such that:
-
• for every $T\geq L$
, there exists a measurable set
$\Gamma ^T=\Gamma ^T(\epsilon /4,\delta _1)\subset \Gamma $
with
$\mu (\Gamma ^T)\geq 1-\delta _1$
; -
• there is a natural number $N=N(T)$
such that for every
$n\geq N$
and every
$x\in \Gamma ^T$
, we have that $$ \begin{align*} \prod_{i=0}^{n-1}\lVert\psi^*_T|_{E_1(\varphi_{iT}(x))}\rVert\leq e^{-(\chi-\epsilon/4)nT}, \quad \prod_{i=0}^{n-1}m(\psi^*_T|_{E_2(\varphi_{iT}(x))})\geq e^{(\chi-\epsilon/4)nT}, \end{align*} $$
$$ \begin{align*} \dfrac{\lVert\psi^*_T|_{E_1}\rVert}{m(\psi^*_T\|_{E_2})}\leq e^{-T(\chi-\epsilon/4)}. \end{align*} $$


Fix an integer
$T_0\geq L(\epsilon /4,\delta _1)$
 and let
$\eta _0=(\chi -\epsilon /4)T_0$
 . For
$k\in \mathbb {N}^+$
 , we define the Pesin block
$\Lambda ^{T_0}_{\eta _0}(k)$
 as

According to [Reference Wu, Yang and Zhang37, Proposition 5.3],
$\Lambda ^{T_0}_{\eta _0}(k)$
 is a compact set and

Therefore, one can fix k large enough such that
$\mu (\Lambda ^{T_0}_{\eta _0}(k))>1-2\delta _1>0$
 . For this fixed k, there is
$j=j(k)\in \mathbb {N}^+$
 such that
$k<e^{{jT_0\epsilon }/{4}}$
 . Thus, for every
$x\in \Lambda ^{T_0}_{\eta _0}(k)$
 , one has that

Set
$\eta =(\chi -\epsilon /2)jT_0$
 ,
$T=jT_0$
 . We consider the set

For
$\epsilon /4>0$
 , there is a number
$\zeta>0$
 such that

Since
$\widetilde {\psi }^*_T$
 and
$(\widetilde {\psi }^*_T)^{-1}$
 are both continuous on

for every
$x_1,~x_2\in M^3\backslash \text {Sing}(X)$
 , denote by

the map

is also continuous. Therefore,
$\mathrm {I}(x_1,x_2)=(\psi ^*_T|_{\mathcal {N}_{x_1}})^{-1}\circ (\psi ^*_T|_{\mathcal {N}_{x_2}})$
 approach to

when both the distance between
$x_1$
 and
$\varphi _T(x_2)$
 , and the distance between
$\varphi _{-T}(x_1)$
 and
$x_2$
 are small enough. Let
$\sigma _1>0$
 satisfy that

Since
$\widetilde {M}$
 is compact,
$\sigma _1$
 always exists. For
$T>0$
 , the norm

is uniformly upper bounded on
$\mathcal {N}$
 and the norm

is uniformly bounded from
$0$
 on
$\mathcal {N}$
 . Since
$\varphi _t$
 is a
$C^1$
 flow, there is
$\sigma ^{\prime }_2>0$
 such that for any
$t_1,~t_2\in \mathbb {R}$
 , we have that

For
$\zeta>0$
 , there is
$\sigma ^{\prime }_2>0$
 such that for every
$s\in (T-\sigma ^{\prime \prime }_2,T+\sigma ^{\prime \prime }_2)$
 and every
$x\in M^3\backslash \text {Sing}(X)$
 , we have that

Let
$\sigma _2=\min \{\sigma ^{\prime }_2,\sigma ^{\prime \prime }_2\}$
 . Then,

Now, we give a claim on invertible linear maps.
Claim. Given two invertible linear maps
$A,~B:\mathbb {R}^d\longrightarrow \mathbb {R}^d$
 . For
$\epsilon _1>0$
 , there is
$\sigma _3>0$
 such that if
$\lVert B-I\rVert \leq \sigma _3$
 , then

Proof of the Claim.
We only need to prove the inequality
$(\S )$
 for
$v\in \mathbb {R}^d$
 with
$\lVert v\rVert =1$
 . Now, we always assume that
$\lVert v\rVert =1$
 . For any
$\epsilon _1>0$
 , let
$\epsilon _2>0$
 satisfying that
$1-\epsilon _2>e^{-\epsilon _1}$
 and

Therefore,

Consequently, if
$\lVert B-I\rVert \leq \sigma _3$
 , we have that

For a given
$x\in M^3$
 and a sufficiently small neighborhood
$U(x)$
 of x, similarly to the technique used in [Reference Pollicott27], by parallel transporting vector along the unique geodesic in the Sasaki metric, we can locally trivialize the tangent bundle
$T_{U(x)}M^3=U(x)\times \mathbb {R}^3$
 of
$U(x)$
 . Thus, for every
$y\in U(x)$
 , we can translate the vectors of
$T_xM^3$
 to
$T_yM^3$
 . Thus, we can translate the vectors of
$\mathcal {N}_x$
 to
$\mathcal {N}_y$
 . According to Lemma 3.1, there is a
$\beta ^*_0>0$
 such that for every
$x\in M^3\backslash \text {Sing}(X)$
 , every point
$y\in U(x)=B(x,\beta ^*_0\lvert X(x)\rvert )$
 is not a singularity. Thus, for every
$v\in \mathcal {N}_y$
 and
$\rho>1$
 , we can define the
$\rho $
 -cone in
$\mathcal {N}_y$
 :

where
$v=v_1+v_2$
 ,
$v_j\in E_j(x)$
 , and
$E_j(x)$
 is the Oseledec subspace with respect to the Lyapunov exponent
$\unicode{x3bb} _j$
 for
$j=1,2$
 . Namely, translating the splitting
$E_1(x)\oplus E_2(x)$
 of
$\mathcal {N}_x$
 to
$\mathcal {N}_y$
 , and for
$v\in \mathcal {N}_y$
 ,
$v=v_1+v_2$
 is the expression corresponding to the splitting. For computation, we can define an equivalent norm
$\lVert \cdot \rVert '$
 on
$\mathcal {N}_y$
 :

Since the Oseledec splitting

is a dominated splitting for
$\psi ^*_T$
 , there exist two positive numbers
$\gamma \in (0,1)$
 and
$\rho>1$
 such that
$\gamma \rho>1$
 and

Furthermore, we can choose
$0<\sigma _4=\sigma _4(\gamma ,\rho )$
 such that for every homeomorphism
$\mathcal {T}$
 , we have that

Take
$y\in \Lambda ^{T}_{\eta }(k)$
 . By Poincaré recurrence theorem, there is an increasing integer sequence
$\{l_n\}$
 such that

Let

For
$0<\varepsilon <\min \{\beta ^*_0,~\xi ,~{r_0}/{K_0},~{\epsilon }/{4},~{\sigma _1}/{2K_0},~{\sigma _2}/{K_0},~\sigma _3,~\log (1+\sigma _4)\}$
 and
${\alpha \in (0,1/k)}$
 , we get a constant
$\delta =\delta (\varepsilon ,\alpha )$
 by Theorem 3.5. For
$l_n$
 large enough, we obtain a
$(\eta ,T)$
 -
$\psi ^*_t$
 -quasi-hyperbolic orbit segment
$\varphi _{[0,l_nT]}(y)$
 satisfying that:
-
• $d(y,\text {Sing}(X))>\alpha $
and
$d(\varphi _{l_nT}(y),\text {Sing}(X))>\alpha $
; -
• $y\in \Lambda ^{T}_{\eta }(k)$
,
$\varphi _{l_nT}(y)\in \Lambda ^{T}_{\eta }(k)$
, and
$d(y,\varphi _{l_nT}(y))<\delta $
.


According to Theorem 3.5, there is a strictly increasing
$C^1$
 function
$\theta :[0,l_nT]\to \mathbb {R}$
 and a periodic point
$p\in M^3$
 such that:
-
(1) $\theta (0)=0$
and
$1-\varepsilon <\theta '(t)<1+\varepsilon $
for every
$t\in [0,l_nT]$
; -
(2) p is periodic, $\varphi _{\theta (l_nT)}(p)=p$
; -
(3) $d(\varphi _t(y),\varphi _{\theta (t)}(p))<\varepsilon \lvert X(\varphi _t(y))\rvert $
for every
$t\in [0,l_nT]$
.


Moreover, by [Reference Wu, Yang and Zhang37, Proposition 4.4], there is constant
$N=N(\eta ,T)$
 such that

Take
$l_n$
 large enough such that

We write
$l_n$
 simply as l when no confusion can arise. Thus, we get a periodic orbit of p with period
$\theta (lT)$
 . Then, we have an invariant measure

supported on the periodic orbit of p. Let

be the Lyapunov exponents of
$\mu _p$
 . To estimate the largest exponent and the smallest exponent, we give the the following claim.
Claim. For every
$i=0,1,\ldots ,l-1$
 , let

We have that

Proof of the Claim.
For every
$i=0,1,\ldots ,l-1$
 , we have that

is identity. Thus, we consider

Since

we have that

It means that
$\theta ((i+1)T)-\theta (iT)\in (T-\sigma _2,T+\sigma _2)$
 for every
$i=0,1,\ldots ,l-1$
 . Therefore,


However, since

we have that

Thus,

Consequently,

Then,

Since

we have that

Since
$1-\varepsilon <\theta '(t)<1+\varepsilon $
 , for every
$t\in [0,lT]$
 , we have that

Therefore,

However, since
$\varepsilon <\log (1+\sigma _4)$
 , by the similar discussions as the claim, we have that

and

Therefore, for each
$i=0,1,\ldots ,l-1$
 , we have that

For every
$v=(v_1,v_2)\in \mathcal {C}_\rho (p)$
 and
$i=0,1,\ldots ,l-1$
 , denote by

and

Corresponding to the Oseledec splitting

denote by

Then, for each
$i=0,1,\ldots ,l-1$
 , we have that

Since
$\mathcal {C}_\rho (p)$
 contains the subspace
$E_2(p)$
 , formulas
$(\Delta )$
 ,
$(1)$
 , and Lemma 4.1 indicate that

This proves the proposition.
Now, we provide some notation and basic facts for the vector field
$-X$
 . Given a vector field
$X\in \mathfrak {X}^1(M^d)$
 , denote by
$-X$
 the vector field which satisfies that
$-X(x)$
 and
$X(x)$
 have opposite directions, and
$\lvert -X(x)\rvert =\lvert X(x)\rvert $
 for every
$x\in M^d$
 . Therefore, the vector field
$-X$
 can also generate a
$C^1$
 flow which is denoted by
$\overline {\varphi _t}$
 . Correspondingly, we can obtain the tangent flow
$\overline {\Phi _t}$
 , the linear Poincaré flow
$\overline {\psi _t}$
 , the extended linear Poincaré flow
$\overline {\widetilde {\psi }_t}$
 , and the scaled linear Poincaré flow
$\overline {\psi ^*_t}$
 .
According to the relationship between
$\overline {\varphi _t}$
 and
$\varphi _t$
 , every ergodic invariant measure
$\mu $
 of
$\varphi _t$
 is also an ergodic invariant measure of
$\overline {\varphi }_t$
 . For an ergodic invariant measure
$\mu $
 which is not concentrated on
$\mathrm {Sing}(-X)$
 , according to the definition of the (scaled) linear Poincaré flow
$\overline {\psi _t}:\mathcal {N}\rightarrow \mathcal {N}$
 and the Oseledec theorem [Reference Oseledec25], for
$\mu $
 -almost every x, there is a positive integer
$k\in [1,d-1]$
 , real numbers
$\overline {\chi _1}<\overline {\chi _2}<\cdots <\overline {\chi _k}$
 , and a measurable
$\overline {\psi _t}$
 -invariant splitting (for simplicity, we omit the base point)

on a normal bundle such that

Denote by

the multiplicities of those Lyapunov exponents. Regardless of the multiplicity, we can rewrite the Lyapunov exponents of
$\mu $
 by
$\overline {\unicode{x3bb} _1}\leq \overline {\unicode{x3bb} _2}\leq \cdots \leq \overline {\unicode{x3bb} _d}$
 . Namely,

According to the relationship between
$-X$
 and X, one finds that

Therefore, for every non-zero vector
$v\in \mathcal {N}$
 , we have that

and

Thus,

where
$\chi _1,\ldots ,\chi _{k}$
 are the Lyapunov exponents of the linear Poincaré flow
$\psi _t$
 (scaled linear Poincaré flow
$\psi ^*_t$
 ) with respect to
$\mu $
 . Furthermore, we have that

Regardless of the multiplicity of Lyapunov exponents, we have that

Based on the above discussion, we can conclude that every ergodic hyperbolic invariant measure of the flow
$\varphi _t$
 is also an ergodic hyperbolic invariant measure of the flow
$\overline {\varphi _t}$
 .
Proposition 5.2. (The approximation of smallest Lyapunov exponent)
Let
$\mu $
 be an ergodic hyperbolic invariant regular measure of the
$C^1$
 star vector field
$X\in \mathfrak {X}^1(M)$
 on a compact three-dimensional smooth Riemannian manifold and
$\unicode{x3bb} _1<\unicode{x3bb} _2$
 be the Lyapunov exponents of
$\mu $
 with respect to the scaled linear Poincaré flow
$\psi ^*_t$
 . For every
$\epsilon>0$
 , there is a hyperbolic periodic point p of
$\varphi _t$
 such that

where
$\unicode{x3bb} _1(p)\leq \unicode{x3bb} _2(p)$
 are the Lyapunov exponents of the periodic measure
$\mu _p$
 with respect to the scaled linear Poincaré flow
$\psi ^*_t$
 .
Proof. We consider the flow
$\overline {\varphi _t}$
 generated by the
$C^1$
 star vector field
$-X\in \mathfrak {X}^1(M)$
 on a compact three-dimensional smooth Riemannian manifold. Then,
$\mu $
 is an ergodic hyperbolic invariant regular measure of the flow
$\overline {\varphi _t}$
 . By Lemma 2.9, every star vector field admits a dominated splitting
$\mathcal {N}_{\text {supp}(\mu )\backslash \text {Sing}(X)}=E\oplus F$
 with respect to the scaled linear Poincaré flow
$\overline {\psi ^*_t}$
 such that
$\mathrm {dim}(E)=\mathrm {Ind}(\mu )$
 . According to the similar discussions on Lyapunov exponents as the two different cases in the proof of Theorem A, we only need to consider the case where one Lyapunov exponent is positive and the other is negative. Namely, the Oseledec splitting
$\mathcal {N}_\Gamma =\overline {E_1}\oplus \overline {E_2}$
 of the ergodic hyperbolic invariant measure
$\mu $
 is a dominated splitting and we have that

where
$\overline {\unicode{x3bb} _1}<0<\overline {\unicode{x3bb} _2}$
 .
Let

Since the Oseledec splitting
$\mathcal {N}_\Gamma =\overline {E_1}\oplus \overline {E_2}$
 is a dominated splitting, by Lemma 4.1, for every
$0<\epsilon /4\ll \overline {\chi }$
 and every
$\delta _2\in (0,1/9)$
 , there is a positive number
$\overline {L}=\overline {L}(\epsilon /4,\delta _2)$
 such that:
-
• for every $T\geq \overline {L}$
, there exists a measurable set
$\overline {\Gamma ^T}=\overline {\Gamma ^T}(\epsilon /4,\delta _2)\subset \Gamma $
with
$\mu (\overline {\Gamma ^T})\geq 1-\delta _2$
; -
• there is a natural number $N=N(T)$
such that for every
$n\geq N$
and every
$x\in \overline {\Gamma ^T}$
, we have that $$ \begin{align*} \prod_{i=0}^{n-1}\lVert\overline{\psi^*_T}\lvert_{\overline{E_1}(\overline{\varphi_{iT}}(x))}\rVert\leq e^{-(\overline{\chi}-\epsilon/4)nT},\quad \prod_{i=0}^{n-1}m(\overline{\psi^*_T}|_{\overline{E_2}(\overline{\varphi_{iT}}(x))})\geq e^{(\overline{\chi}-\epsilon/4)nT}, \end{align*} $$
$$ \begin{align*} \dfrac{\lVert\overline{\psi^*_T}|_{\overline{E_1}(x)}\rVert}{m(\overline{\psi^*_T}|_{\overline{E_2}(x)})}\leq e^{-T(\overline{\chi}-\epsilon/4)}. \end{align*} $$


Fix an integer
$T_0\geq \overline {L}(\epsilon /4,\delta _2)$
 and let
$\eta _0=(\overline {\chi }-\epsilon /4)T_0$
 . For
$k\in \mathbb {N}^+$
 , we define the Pesin block
$\Lambda ^{T_0}_{\eta _0}(k)$
 with respect to the scaled linear Poincaré flow
$\overline {\psi ^*_t}$
 as

According to [Reference Wu, Yang and Zhang37, Proposition 5.3],
$\Lambda ^{T_0}_{\eta _0}(k)$
 is a compact set and

Therefore, one can fix k large enough such that
$\mu (\Lambda ^{T_0}_{\eta _0}(k))>1-2\delta _2>0$
 . For this fixed k, there is
$j=j(k)\in \mathbb {N}^+$
 such that
$k<e^{{jT_0\epsilon }/{4}}$
 . Thus, for every
$x\in \Lambda ^{T_0}_{\eta _0}(k)$
 , one has that

Set
$\eta =(\overline {\chi }-\epsilon /2)jT_0$
 ,
$T=jT_0$
 , we consider the set

Take
$y\in \Lambda ^{T}_{\eta }(k)$
 . By Poincaré recurrence theorem, there is an increasing integer sequence
$\{l_n\}$
 such that

By a discussion similar to Proposition 5.1, we conclude that there exists a periodic point p of
$\overline {\varphi }_t$
 such that

where
$\overline {\unicode{x3bb} _1}(p)\leq \overline {\unicode{x3bb} _2}(p)$
 are the Lyapunov exponents of
$\mu _p$
 with respect to the scaled linear Poincaré flow
$\overline {\psi ^*_t}$
 . According to the relationship between the Lyapunov exponents of the scaled linear Poincaré flow
$\overline {\psi ^*_t}$
 and those of the scaled linear Poincaré flow
$\psi ^*_t$
 , we have that

Thus,

This completes the proof.
Proof of Theorem B.
Given
$\varepsilon>0$
 small enough, let

where
$L({\varepsilon }/{4},\delta _1)$
 given in Proposition 5.1 and
$\overline {L}({\varepsilon }/{4},\delta _2)$
 given in Proposition 5.2. For
$T\geq L$
 , the set

is a
$\mu $
 -positive set. For the
$\varepsilon>0$
 , by Propositions 5.1 and 5.2, there is a periodic point p such that the Lyapunov exponents of
$\mu _p$
 satisfy that

where
$\unicode{x3bb} _1(p)\leq \unicode{x3bb} _2(p)$
 are the Lyapunov exponents of
$\mu _p$
 .
Acknowledgements
W. Wu is the corresponding author and was supported by NSFC (Grant Nos. 12001245, 12471185).



