1 Introduction
Magnetic field line topology has been recognized to be a crucial part in the evolution of magnetic fields in magnetohydrodynamics (MHD), see Woltjer (Reference Woltjer1958), Parker (Reference Parker1972), Taylor (Reference Taylor1974), Frisch et al. (Reference Frisch, Pouquet, Léorat and Mazure1975), Kleeorin & Ruzmaikin (Reference Kleeorin and Ruzmaikin1982), Hornig & Schindler (Reference Hornig and Schindler1996), Del Sordo, Candelaresi & Brandenburg (Reference Del Sordo, Candelaresi and Brandenburg2010), Yeates, Hornig & Wilmot-Smith (Reference Yeates, Hornig and Wilmot-Smith2010), Wilmot-Smith, Pontin & Hornig (Reference Wilmot-Smith, Pontin and Hornig2010) and Candelaresi & Brandenburg (Reference Candelaresi and Brandenburg2011). The most used quantifier of the field’s topology is the magnetic helicity (Moffatt Reference Moffatt1969; Arnold Reference Arnold1974; Berger & Field Reference Berger and Field1984; Enciso, Peralta-Salas & de Lizaur Reference Enciso, Peralta-Salas and de Lizaur2016) which measures the linking, braiding and twisting of the field lines. Through Arnold’s inequality (Arnold Reference Arnold1974) it imposes a lower bound for the magnetic energy. As the magnetic helicity is a (second order) invariant under non-dissipative evolution (non-resistive) it imposes restrictions on the evolution of the magnetic field. A further topological invariant
 $M$
of topological complexity
 $7$
can be found (Akhmet’ev Reference Akhmet’ev2014) (the idea of the construction is presented in Ruzmaikin & Akhmetiev (Reference Ruzmaikin and Akhmetiev1994)).
 $M$
is a generalized helicity integral and constitutes a more effective lower bound for magnetic energy compared to the magnetic helicity. Informally,
 $M$
is a measure of how much the magnetic lines are of the shape of helical Borromean rings. Second-order invariants are the field line helicity (Yeates & Hornig Reference Yeates and Hornig2011; Russell et al.
Reference Russell, Yeates, Hornig and Wilmot-Smith2015) that measures a weighted average helicity along magnetic field lines, and the two quadratic helicities
 $\unicode[STIX]{x1D712}^{(2)}$
,
 $\unicode[STIX]{x1D712}^{[2]}$
, which are to be considered as the
 $L^{2}$
-norms of field line helicity. The main problem in applying the high-order helicity is related to its calculation. A local formula for quadratic helicity
 $\unicode[STIX]{x1D712}^{(2)}$
is proposed by Akhmet’ev, Candelaresi & Smirnov (Reference Akhmet’ev, Candelaresi and Smirnov2017).
In this work we consider another approach to calculating the quadratic helicities of special cases of magnetic fields, which is based on the ergodic theorem. Those are eigenvectors of the curl operator, implying that the field is also force free, i.e. the Lorentz force vanishes. We first introduce these fields and discuss some general properties by applying the Lobachevskii geometry to MHD. Then we show that they constitute quasi-stationary solutions of the ideal incompressible MHD equations by using geodesic flows (Dehornoy Reference Dehornoy2015). This is done on special manifolds equipped with a prescribed Riemannian metric, which corresponds to a dynamics of the Anosov type. Using the geodesic flow construction, we apply the results from hyperbolic dynamics to calculate higher invariants of the magnetic field of which presented calculations of quadratic helicities are the simplest examples. Finally, we show that those fields constitute minimal quadratic helicity states.
2 Eigenfunctions of the curl operator
2.1 Positive eigenfunction
We recall formula for a Hopf magnetic field, a generalization is presented in Semenov, Korovinski & Biernat (Reference Semenov, Korovinski and Biernat2002). Let
 $S^{3}$
be the standard
 $3$
-sphere
 $$\begin{eqnarray}S^{3}=\{z_{1},z_{2}|z_{1}\bar{z_{1}}+z_{2}\bar{z_{2}}=1\},\quad z_{1},z_{2}\in \mathbb{C},\end{eqnarray}$$
equipped with the standard Riemannian metric
 $g$
. Let
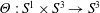 $\unicode[STIX]{x1D6E9}:S^{1}\times S^{3}\rightarrow S^{3}$
be the standard action of the unit complex circle, given by
 $$\begin{eqnarray}\unicode[STIX]{x1D6E9}(\unicode[STIX]{x1D711};z_{1},z_{2})=(z_{1}\exp (\boldsymbol{i}\unicode[STIX]{x1D711}),z_{2}\exp (\boldsymbol{i}\unicode[STIX]{x1D711})).\end{eqnarray}$$
Let
 $\boldsymbol{B}_{\text{right}}=\text{d}\unicode[STIX]{x1D6E9}/\text{d}\unicode[STIX]{x1D711}$
be the Hopf magnetic field on
 $S^{3}$
, which is tangent to the Hopf fibres (fibres of
 $\unicode[STIX]{x1D6E9}$
).
Lemma 1. Consider the operator
 $\mathbf{rot}$
on the Riemannian manifold
 $(S^{3},g)$
(see for the definition Arnol’d & Khesin (Reference Arnol’d and Khesin2013) I.9.5), we get:
 $$\begin{eqnarray}\mathbf{rot}\,\boldsymbol{B}_{\text{right}}(\boldsymbol{x})=2\boldsymbol{B}_{\text{right}}(\boldsymbol{x}),\quad \boldsymbol{x}\in S^{3}.\end{eqnarray}$$
Proof. This is Example 5.2 in Arnold (Reference Arnold1974). However, we show here direct calculations of this lemma. For that we define the curve
 $\unicode[STIX]{x1D6E9}$
on
 $\mathbb{R}^{4}$
rather than on
 $\mathbb{C}^{2}$
:
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D6E9}(\unicode[STIX]{x1D711},x_{0},x_{1},x_{2},x_{3}) & = & \displaystyle (x_{0}\cos (\unicode[STIX]{x1D711})-x_{1}\sin (\unicode[STIX]{x1D711}),x_{0}\sin (\unicode[STIX]{x1D711})+x_{1}\cos (\unicode[STIX]{x1D711}),\nonumber\\ \displaystyle & & \displaystyle x_{2}\cos (\unicode[STIX]{x1D711})-x_{3}\sin (\unicode[STIX]{x1D711}),x_{2}\sin (\unicode[STIX]{x1D711})+x_{3}\cos (\unicode[STIX]{x1D711})),\end{eqnarray}$$
with the coordinates
 $x_{0}$
,
 $x_{1}$
,
 $x_{2}$
and
 $x_{3}$
. From that we can compute
 $\boldsymbol{B}_{\text{right}}=\text{d}\unicode[STIX]{x1D6E9}/\text{d}\unicode[STIX]{x1D711}$
from which we define the associated differential one-form on
 $\mathbb{R}^{4}$
:
 $$\begin{eqnarray}\unicode[STIX]{x1D6FD}_{\text{right}}^{\text{R4}}=B_{\text{right}}^{0}\text{d}x^{0}+B_{\text{right}}^{1}\text{d}x^{1}+B_{\text{right}}^{2}\text{d}x^{2}+B_{\text{right}}^{3}\text{d}x^{3}.\end{eqnarray}$$
We now define the mapping between points on the three-sphere
 $S^{3}$
and
 $\mathbb{R}^{4}$
:
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}\displaystyle \unicode[STIX]{x1D6F9}=(x_{0},x_{1},x_{2},x_{3})\\ \displaystyle x_{0}=\cos (\unicode[STIX]{x1D703}_{1})\\ \displaystyle x_{1}=\sin (\unicode[STIX]{x1D703}_{1})\cos (\unicode[STIX]{x1D703}_{2})\\ \displaystyle x_{2}=\sin (\unicode[STIX]{x1D703}_{1})\sin (\unicode[STIX]{x1D703}_{2})\cos (\unicode[STIX]{x1D703}_{3})\\ x_{3}=\sin (\unicode[STIX]{x1D703}_{1})\sin (\unicode[STIX]{x1D703}_{2})\sin (\unicode[STIX]{x1D703}_{3}),\end{array}\right\}\end{eqnarray}$$
with the coordinates of
 $S^{3}$
:
 $\unicode[STIX]{x1D703}_{1}\in [0,2\unicode[STIX]{x03C0})$
,
 $\unicode[STIX]{x1D703}_{2}\in [0,\unicode[STIX]{x03C0}]$
and
 $\unicode[STIX]{x1D703}_{3}\in [0,\unicode[STIX]{x03C0}]$
. We can now compute the differential one-form
 $\unicode[STIX]{x1D6FD}_{\text{right}}^{\text{R4}}$
on
 $S^{3}$
as the pull-back under the mapping
 $\unicode[STIX]{x1D6F9}$
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D6FD}_{\text{right}}^{\text{S3}} & = & \displaystyle \unicode[STIX]{x1D6F9}^{\ast }\unicode[STIX]{x1D6FD}_{\text{right}}^{\text{R4}}\nonumber\\ \displaystyle & = & \displaystyle \cos (\unicode[STIX]{x1D711})\cos (\unicode[STIX]{x1D703}_{2})\,\text{d}\unicode[STIX]{x1D703}^{1}-\cos (\unicode[STIX]{x1D711})\cos (\unicode[STIX]{x1D703}_{1})\sin (\unicode[STIX]{x1D703}_{1})\sin (\unicode[STIX]{x1D703}_{2})\,\text{d}\unicode[STIX]{x1D703}^{2}\nonumber\\ \displaystyle & & \displaystyle +\,\cos (\unicode[STIX]{x1D711})\sin ^{2}(\unicode[STIX]{x1D703}_{1})\sin ^{2}(\unicode[STIX]{x1D703}_{2})\,\text{d}\unicode[STIX]{x1D703}^{3}.\end{eqnarray}$$
The curl operation on the vector field
 $\boldsymbol{B}_{\text{right}}^{S3}$
corresponds to the exterior differential of the one-form
 $\unicode[STIX]{x1D6FD}_{\text{right}}^{S3}$
which results in a two-form
 $\text{d}\unicode[STIX]{x1D6FD}_{\text{right}}^{S3}$
. We take it’s Hodge-dual
 $\star \text{d}\unicode[STIX]{x1D6FD}_{\text{right}}^{S3}$
, with the volume element
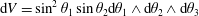 $\text{d}V=\sin ^{2}\unicode[STIX]{x1D703}_{1}\sin \unicode[STIX]{x1D703}_{2}\text{d}\unicode[STIX]{x1D703}_{1}\wedge \text{d}\unicode[STIX]{x1D703}_{2}\wedge \text{d}\unicode[STIX]{x1D703}_{3}$
, compare it with
 $\unicode[STIX]{x1D6FD}_{\text{right}}^{S3}$
and find
 $$\begin{eqnarray}\displaystyle \star \text{d}\unicode[STIX]{x1D6FD}_{\text{right}}^{S3} & = & \displaystyle 2\cos (\unicode[STIX]{x1D711})\cos (\unicode[STIX]{x1D703}_{2})\,\text{d}\unicode[STIX]{x1D703}^{1}-2\cos (\unicode[STIX]{x1D711})\cos (\unicode[STIX]{x1D703}_{1})\sin (\unicode[STIX]{x1D703}_{1})\sin (\unicode[STIX]{x1D703}_{2})\,\text{d}\unicode[STIX]{x1D703}^{2}\nonumber\\ \displaystyle & & \displaystyle +\,2\cos (\unicode[STIX]{x1D711})\sin ^{2}(\unicode[STIX]{x1D703}_{1})\sin ^{2}(\unicode[STIX]{x1D703}_{2})\,\text{d}\unicode[STIX]{x1D703}^{3}.\end{eqnarray}$$
Hence the result
 $$\begin{eqnarray}\star \text{d}\unicode[STIX]{x1D6FD}_{\text{right}}^{\text{S3}}=2\unicode[STIX]{x1D6FD}_{\text{right}}^{\text{S3}},\end{eqnarray}$$
which corresponds to (2.3).
The left transformation of
 $S^{3}$
(see the beginning of the next section for the right transformation) is transitive and is an isometry. This isometry commutes with the curl operator and keeps the Hopf fibration (which is determined by the right
 $\boldsymbol{i}$
-multiplication). This proves the (2.3) at an arbitrary point on
 $S^{3}$
.
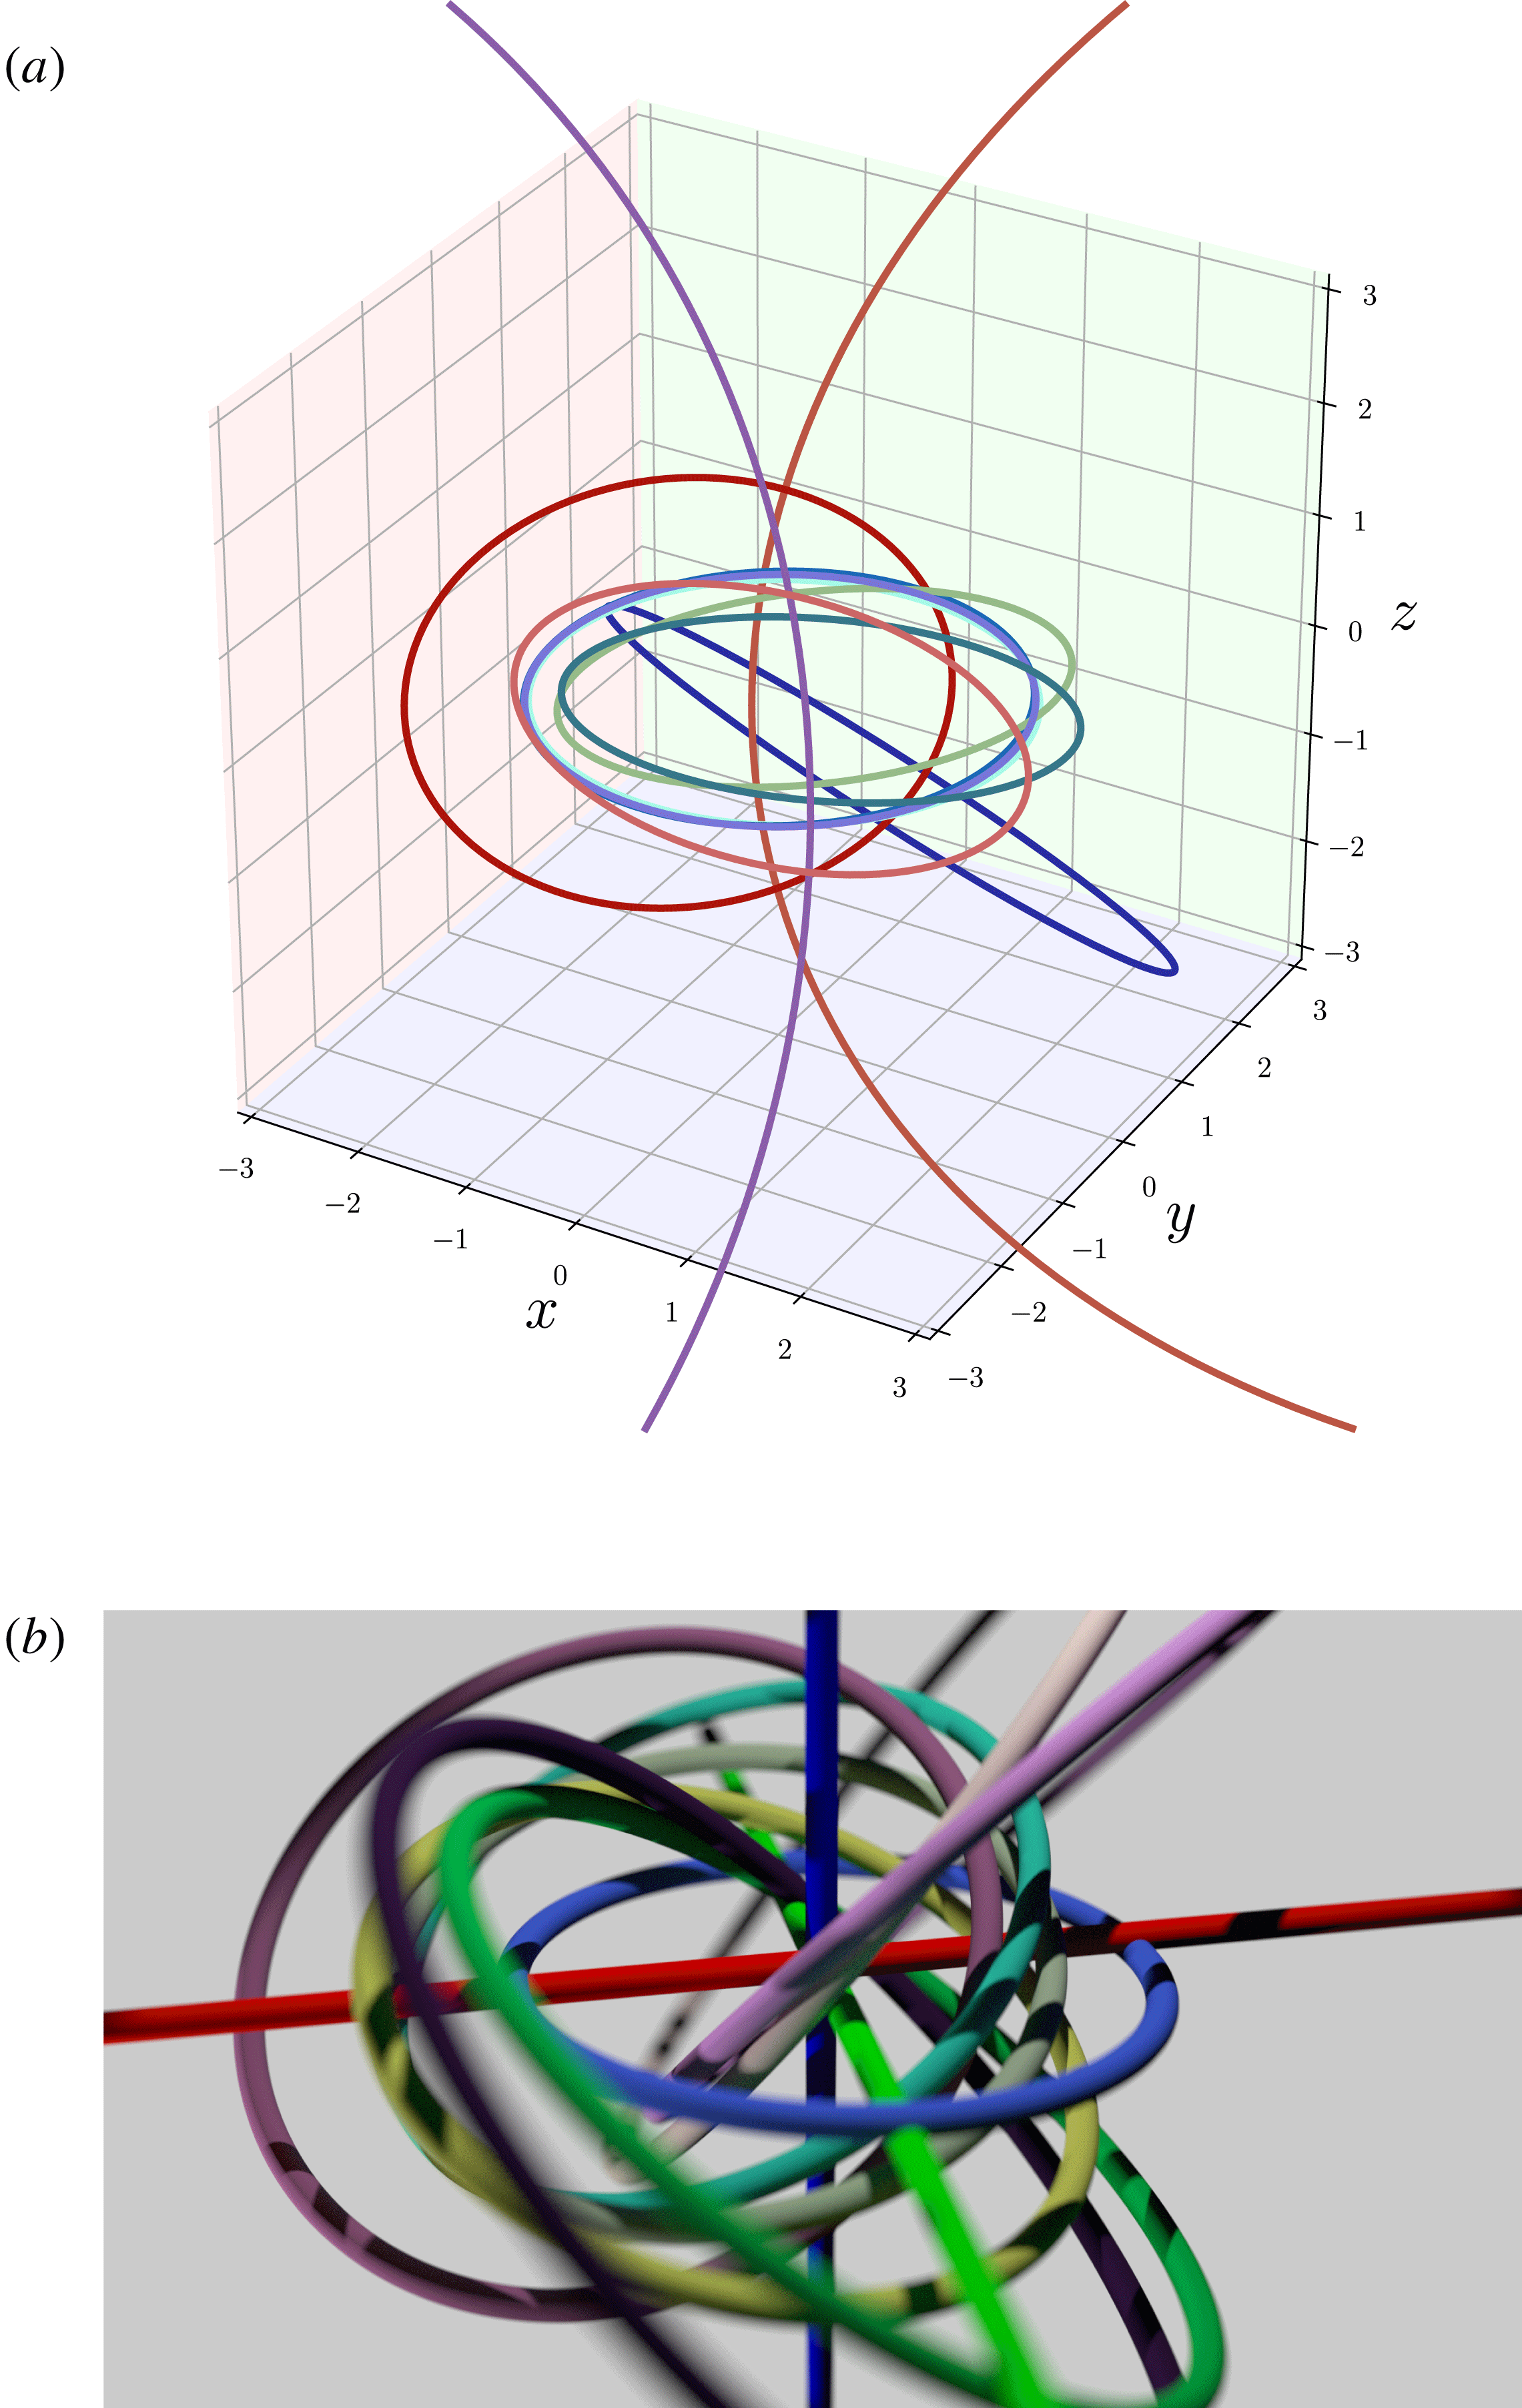
Using a simple stereographic projection we can plot the field lines for
 $\boldsymbol{B}_{\text{right}}$
(see figure 1). The traced field lines are simply the Hopf rings, mutually linked circles that fill
 $\mathbb{R}^{3}$
.
Two plots for the field
 $\boldsymbol{B}_{\text{right}}$
in stereographic projection. Here we use a few random field lines to showcase the nature of this field. In (b) the axes are
 $x$
(red),
 $y$
(green) and
 $z$
(blue).

It is natural to investigate the Hopf magnetic vector field from Hamiltonian dynamics. Consider the standard symplectic form
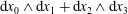 $\text{d}x_{0}\wedge \text{d}x_{1}+\text{d}x_{2}\wedge \text{d}x_{3}$
in
 $\mathbb{R}^{4}$
. Consider the Hamiltonian
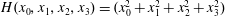 $H(x_{0},x_{1},x_{2},x_{3})=(x_{0}^{2}+x_{1}^{2}+x_{2}^{2}+x_{3}^{2})$
. Obviously, the Hopf magnetic field
 $2\boldsymbol{B}_{\text{right}}$
determines the Hamilton flow for
 $H=1$
. In a general case a Hamilton flow is divergence free, because it keeps the symplectic structure and the Hamiltonian. Thus, the fundamental
 $3$
-form
 $\text{d}\unicode[STIX]{x1D6FA}$
on the prescribed energy level
 $H=\text{const.}$
has to be defined by the formula
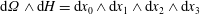 $\text{d}\unicode[STIX]{x1D6FA}\wedge \text{d}H=\text{d}x_{0}\wedge \text{d}x_{1}\wedge \text{d}x_{2}\wedge \text{d}x_{3}$
. In the example the flow
 $\boldsymbol{B}_{\text{right}}$
is integrable: the functions
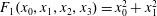 $F_{1}(x_{0},x_{1},x_{2},x_{3})=x_{0}^{2}+x_{1}^{2}$
,
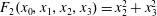 $F_{2}(x_{0},x_{1},x_{2},x_{3})=x_{2}^{2}+x_{3}^{2}$
are first integrals. After a small generic perturbation of the standard symplectic form
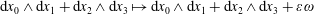 $\text{d}x_{0}\wedge \text{d}x_{1}+\text{d}x_{2}\wedge \text{d}x_{3}\mapsto \text{d}x_{0}\wedge \text{d}x_{1}+\text{d}x_{2}\wedge \text{d}x_{3}+\unicode[STIX]{x1D700}\unicode[STIX]{x1D714}$
, where coefficients of the
 $2$
-form
 $\unicode[STIX]{x1D714}$
depend on points in
 $\mathbb{R}^{4}$
, we obtain a non-integrable system with chaotic magnetic lines. The examples from Semenov et al. (Reference Semenov, Korovinski and Biernat2002) correspond to the non-small perturbation
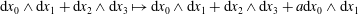 $\text{d}x_{0}\wedge \text{d}x_{1}+\text{d}x_{2}\wedge \text{d}x_{3}\mapsto \text{d}x_{0}\wedge \text{d}x_{1}+\text{d}x_{2}\wedge \text{d}x_{3}+a\text{d}x_{0}\wedge \text{d}x_{1}$
, which admits closed knotted magnetic lines for a rational parameter
 $a$
.
2.2 Preliminary discussion
In the next section a notion for geodesic flows on surfaces is required. The Hopf magnetic field represents the universal (
 $2$
-sheets) covering over the geodesic flow on the standard 2-sphere
 $S^{2}$
. The geodesic flow is a dynamic system on three-dimensional manifold
 $\unicode[STIX]{x1D6EC}(S^{2})$
, which is the spherization of the tangent bundle of
 $S^{2}$
. A point on the manifold
 $\unicode[STIX]{x1D6EC}(S^{2})$
is the pair
 $(x\in S^{2},\vec{\unicode[STIX]{x1D709}}_{x})$
, where
 $\vec{\unicode[STIX]{x1D709}}_{x}$
is a unit tangent
 $S^{2}$
, attached at the point
 $x\in S^{2}$
. The manifold
 $\unicode[STIX]{x1D6EC}(S^{2})$
is diffeomorphic to the transformation group
 $SO(3)$
. To prove this, it is sufficient to consider
 $S^{2}\subset \mathbb{R}^{3}$
. Each point
 $(x,\vec{\unicode[STIX]{x1D709}}_{x})$
determines a
 $2$
-orthogonal base in
 $\mathbb{R}^{3}$
that is a point on manifold
 $SO(3)$
. The manifold
 $SO(3)$
is the base of the double covering
 $S^{3}\rightarrow SO(3)$
.
The tautological vector field
 $\vec{\unicode[STIX]{x1D709}}_{x}$
on
 $T(\unicode[STIX]{x1D6EC}(S^{2}))$
determines the Hamiltonian dynamic system, which is called the geodesic flow. A point
 $x\in S^{2}$
moves along
 $\vec{\unicode[STIX]{x1D709}}_{x}$
. The geodesic flow, lifted on the universal covering
 $S^{3}$
, determines the magnetic (divergence free) vector field, which is called the horizontal magnetic field on
 $S^{3}$
. The Hopf vector field is called the vertical vector field. This vector field corresponds to the rotation of fibres of the standard projection
 $\unicode[STIX]{x1D6EC}(S^{2})\rightarrow S^{2}$
.
By the same argument one may define the geodesic field on
 $\unicode[STIX]{x1D6EC}(M^{2})$
, where
 $M^{2}$
is a surface of a constant negative scalar curvature. One may take
 $M^{2}$
as the closed surface of a constant Riemann surface (with a constant negative scalar curvature). However, this example is not suitable for MHD, because
 $\unicode[STIX]{x1D6EC}(M^{2})$
admits a complicated homotopy type.
The surface
 $M^{2}$
can be non-compact and may coincide with the standard Lobachevskii plane
 $L^{2}$
. In this case
 $\unicode[STIX]{x1D6EC}(L^{2})$
also is non-compact. One may take an isometric action
 $G\times L^{2}\rightarrow L^{2}$
with locally finite orbits. The group
 $G$
is called a Fuchsian group. This action can have fixed points. In this case the manifold
 $\unicode[STIX]{x1D6EC}(L^{2})$
admits the quotient
 $\unicode[STIX]{x1D6EC}(L^{2})/G$
. This quotient can be considered as an interior of a closed Riemannian three-dimensional manifold, with a metric that has singularities (pinches). For many examples
 $\unicode[STIX]{x1D6EC}(L^{2})/G$
is a branching covering over the standard
 $S^{3}$
-sphere, equipped with the Riemannian metric, which corresponds to the standard geodesic metric on
 $\unicode[STIX]{x1D6EC}(L^{2})$
. We observe that in many cases of
 $G$
this
 $\unicode[STIX]{x1D6EC}(L^{2})/G$
admits a Riemannian metric, which is the conformal equivalent to the standard metric on
 $S^{3}$
. We consider the most fundamental example of
 $G$
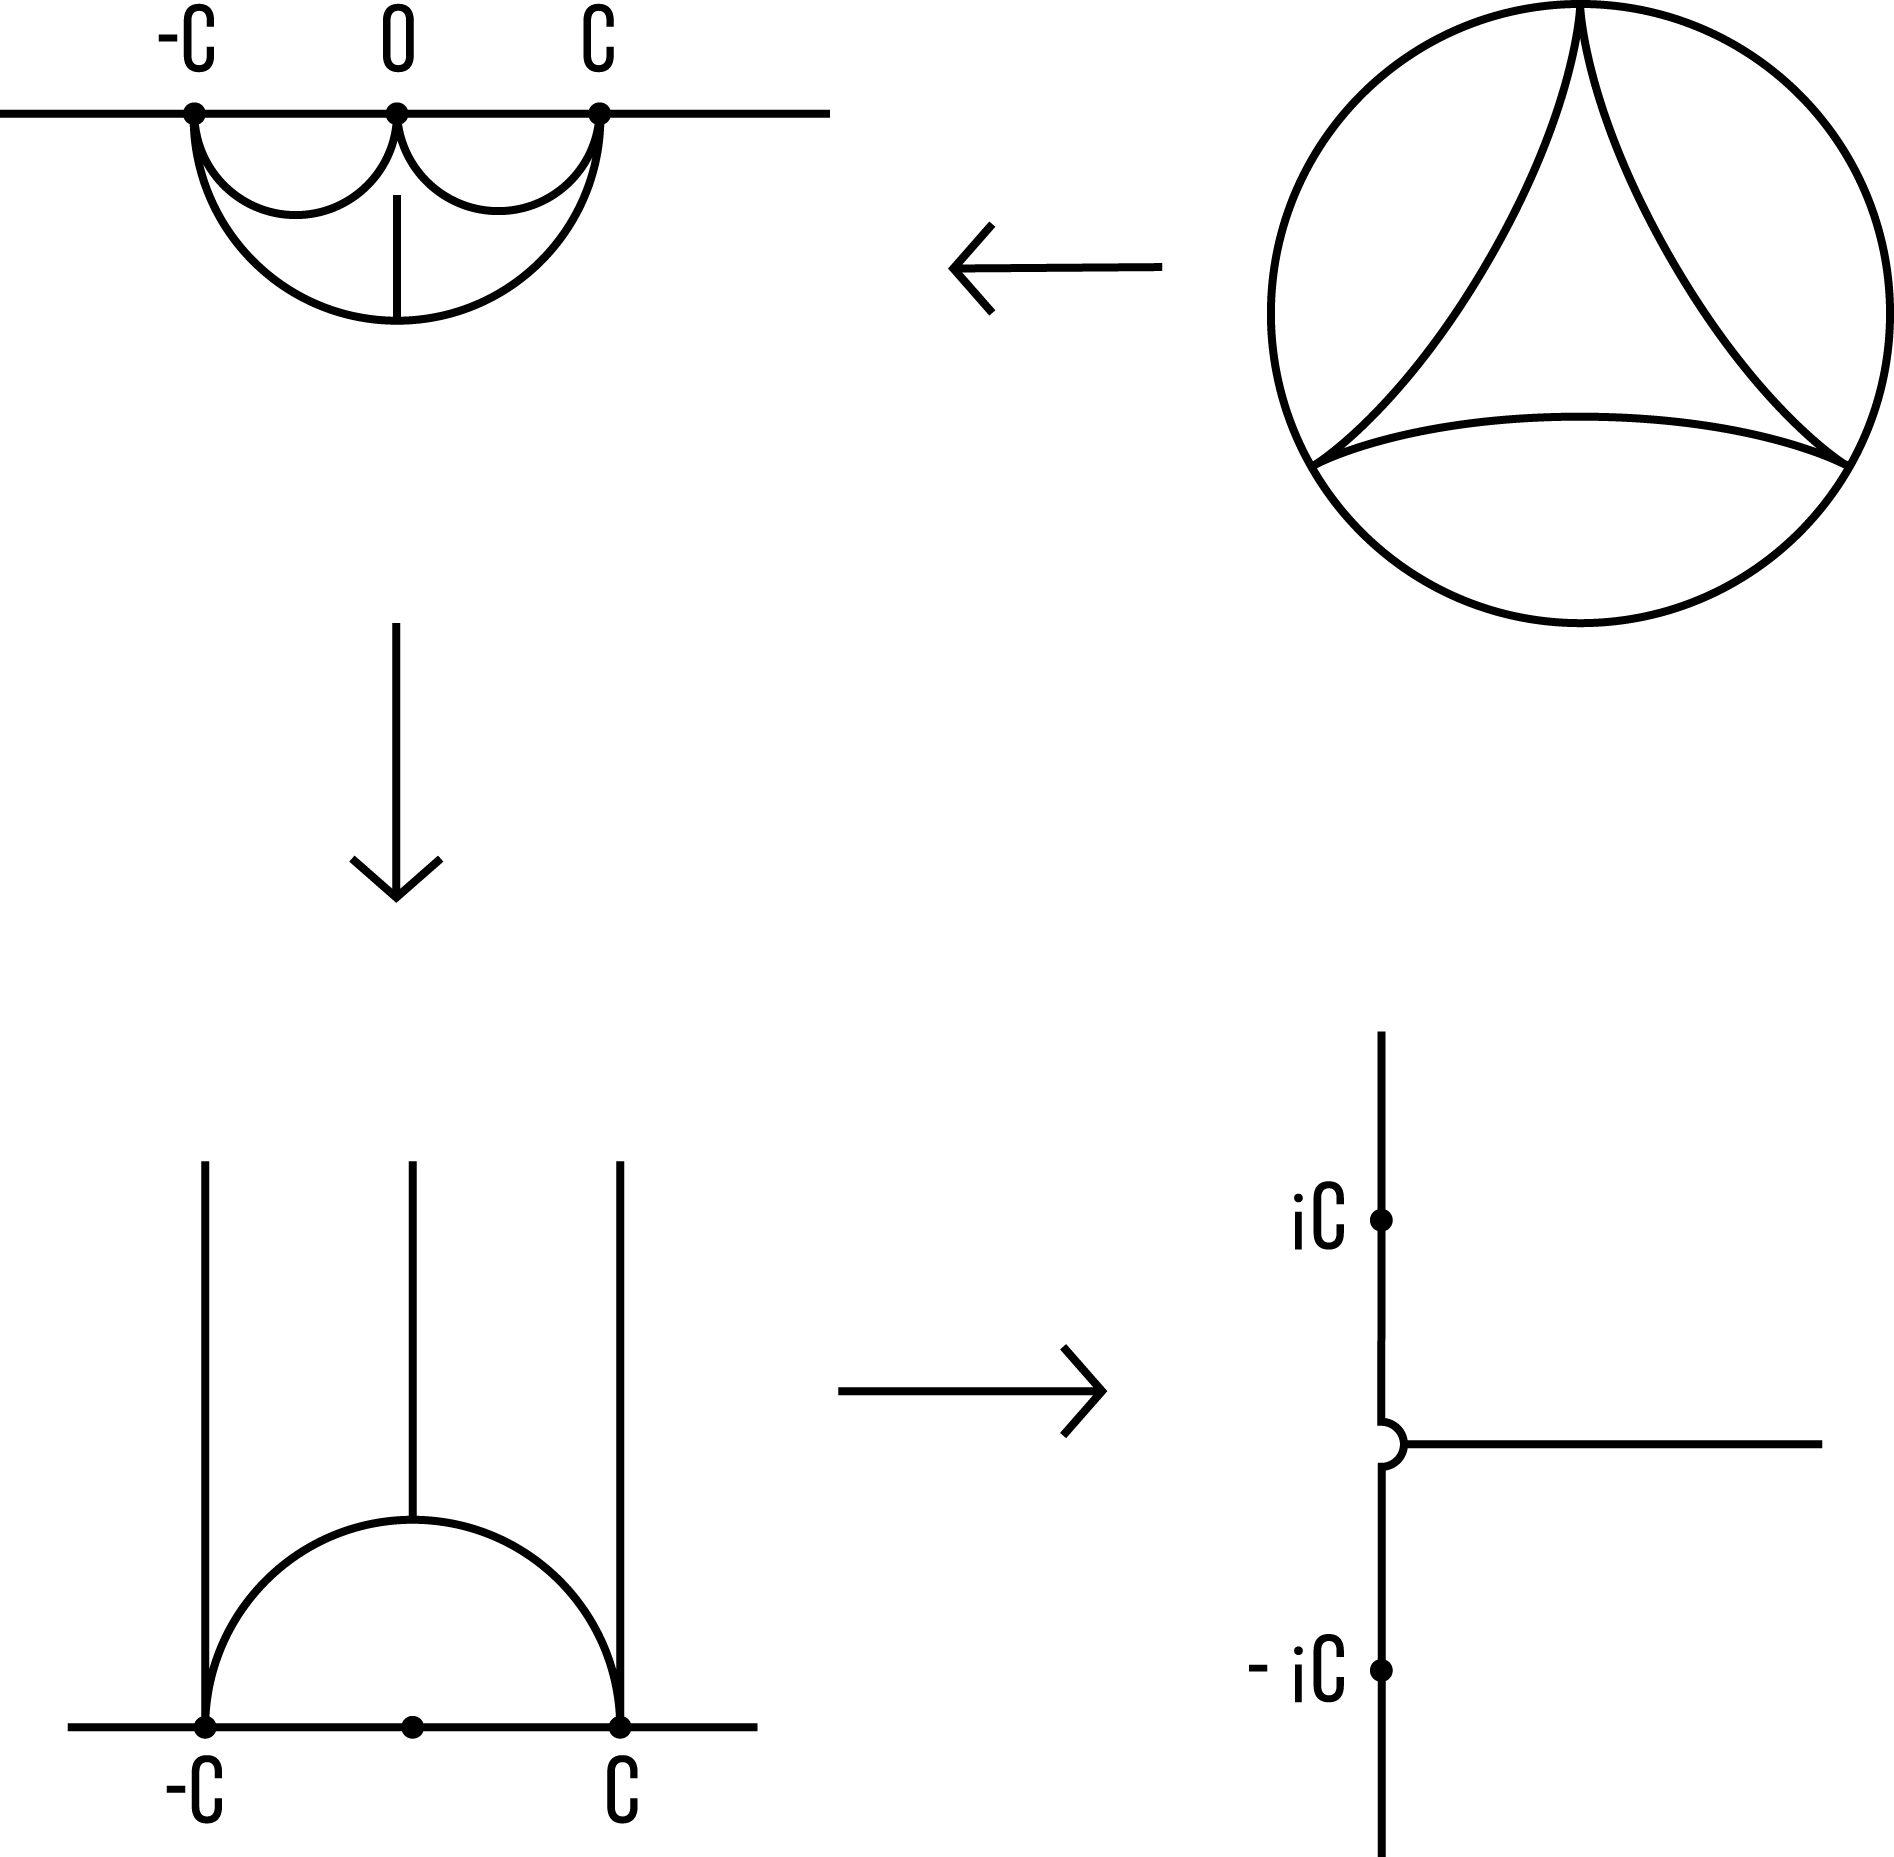
, which is called the modular group. The fundamental domain of the modular group is shown in figure 2. There are two generators: the generator of the order 3 acts by the rotation through the angle
 $2\unicode[STIX]{x03C0}/3$
at the central triangle, the generator of the order 2 acts by the central symmetry through a point at the boundary geodesic line of the triangle. These two generators are not commuted and the modular group is the non-commutative product
 $\boldsymbol{Z}_{3}\ast \boldsymbol{Z}_{2}$
.
A transformation of the standard hyperbolic triangle onto the Riemannian half-sphere by the modular function.

We interpret the geodesic flow on
 $\unicode[STIX]{x1D6EC}(L^{2})/G$
as a force-free magnetic field on
 $S^{3}$
(§ 3) and as MHD solitons (§ 4), which are generalizations of the Hopf magnetic field. The scalar factor of the metric we interpret as density on
 $S^{3}$
, while ramifications curves we interpret as magnetic pinches. The example of the geodesic flow with the modular group
 $G$
in dynamical systems was considered by Ghys & Leys (Reference Ghys and Leys2006). In MHD this gives a testing example to calculate higher invariants of magnetic fields.
Let us briefly explain the reason for investigating magnetic fields using this technique. The present trend in solar physics and cosmology is to investigate the complicated fine structure of observable magnetic fields in non-homogeneous space. For that, stability conditions for magnetic lines are required. The Hopf magnetic field is a force-free configuration with the global minimum of the magnetic energy, as was discovered by Arnold (Reference Arnold1974). This configuration corresponds to an integrable dynamics. After a small perturbation we get a non-integrable dynamics with complicated chaotic field lines. For hyperbolic geodesic flows the situation is the opposite. The dynamic of the modular group itself is non-integrable, but the trajectories are pursued in the sense of Anosov (Reference Anosov1967). After a small perturbation, the properties of the dynamics survive because of the Anosov condition, discovered by Anosov in his famous paper ‘Geodesic flows on closed Riemannian manifolds of negative curvature’ (Anosov Reference Anosov1967).
2.3 Negative eigenfunction
The magnetic field
 $\boldsymbol{B}_{\text{right}}$
is generalized by the following construction. Take
 $S^{3}$
as the unit quaternions
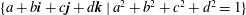 $\{a+b\boldsymbol{i}+c\boldsymbol{j}+d\boldsymbol{k}\mid a^{2}+b^{2}+c^{2}+d^{2}=1\}$
. Take a tangent quaternion
 $\unicode[STIX]{x1D709}\in T_{\boldsymbol{x}=1}(S^{3})$
and define the vector field
 $\boldsymbol{B}_{\text{right}}(\boldsymbol{x})=\boldsymbol{x}\unicode[STIX]{x1D709}$
by the right multiplication. In the case
 $\unicode[STIX]{x1D709}=\boldsymbol{i}$
we get the vector field from Lemma 1. In the case
 $\unicode[STIX]{x1D709}=\boldsymbol{j}$
the vector field
 $\boldsymbol{B}_{\text{right}}$
is not invariant with respect to the action
 $\unicode[STIX]{x1D6E9}$
along the Hopf fibres. To get the invariant vector field
 $\boldsymbol{B}_{\text{left}}$
we define
 $\boldsymbol{B}_{\text{left}}=\boldsymbol{j}\boldsymbol{x}$
,
 $\boldsymbol{x}\in S^{3}$
, by the left multiplication. We get:
 $$\begin{eqnarray}\mathbf{rot}\,\boldsymbol{B}_{\text{left}}(\boldsymbol{x})=-2\boldsymbol{B}_{\text{left}}(\boldsymbol{x}),\quad \boldsymbol{x}\in S^{3}.\end{eqnarray}$$
This follows from the fact that the conjugation
 $$\begin{eqnarray}(a+b\boldsymbol{i}+c\boldsymbol{j}+d\boldsymbol{k})^{\ast }\mapsto a-b\boldsymbol{i}-c\boldsymbol{j}-d\boldsymbol{k},\end{eqnarray}$$
which is an antiautomorphism and an isometry, transforms right vector fields to left vector fields. This antiautomorphism changes the orientation on
 $S^{3}$
. Therefore, equation (2.3) for the vector field
 $\boldsymbol{B}_{\text{right}}$
implies (2.10) for
 $\boldsymbol{B}_{\text{left}}$
.
The vector field
 $\boldsymbol{B}_{\text{left}}$
admits an alternative description by means of geodesic flows on the Riemann sphere
 $S^{2}$
in the following way. The sphere
 $(S^{3},g)$
is diffeomorphic to the universal (2-sheeted) covering over the manifold
 $SO(3)$
, equipped with the standard Riemannian metric. The manifold
 $SO(3)$
is diffeomorphic to the spherization of the tangent bundle over the standard 2-sphere
 $S^{2}$
, denoted by
 $\unicode[STIX]{x1D6EC}(S^{2})$
. The projection
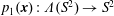 $p_{1}(\boldsymbol{x}):\unicode[STIX]{x1D6EC}(S^{2})\rightarrow S^{2}$
,
 $\boldsymbol{x}\in \unicode[STIX]{x1D6EC}(S^{2})$
is well defined. A circle fibre over
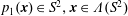 $p_{1}(\boldsymbol{x})\in S^{2},\boldsymbol{x}\in \unicode[STIX]{x1D6EC}(S^{2})$
is visualized as a great circle
 $S^{1}\subset S^{2}$
, with the centre
 $p_{1}(\boldsymbol{x})$
, equipped with the prescribed orientation.
Consider the spherization of the (trivial) tangent bundle over the plane
 $\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
. Denote by
 $\boldsymbol{B}_{\text{left}}$
the magnetic field on
 $\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
, which is tangent to the geodesic flow. The natural Riemannian metric
 $h$
on
 $\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
coincides with the standard metric of the decomposition
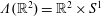 $\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})=\mathbb{R}^{2}\times S^{1}$
.
Lemma 2. The equation:
 $$\begin{eqnarray}\mathbf{rot}\,\boldsymbol{B}_{\text{left}}(\boldsymbol{x})=-\boldsymbol{B}_{\text{left}}(\boldsymbol{x}),\quad \boldsymbol{x}\in \unicode[STIX]{x1D6EC}(\mathbb{R}^{2}),\end{eqnarray}$$
in the metric
 $h$
is satisfied.
Proof. The manifold
 $\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
is equipped with the projection
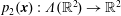 $p_{2}(\boldsymbol{x}):\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})\rightarrow \mathbb{R}^{2}$
. Take the Cartesian coordinates in
 $\mathbb{R}^{2}$
and the coordinate
 $\unicode[STIX]{x1D711}$
along the fibres. In the coordinates
 $(x,y,\unicode[STIX]{x1D711})$
on
 $\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
the magnetic field
 $\boldsymbol{B}$
is defined as
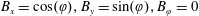 $B_{x}=\cos (\unicode[STIX]{x1D711}),B_{y}=\sin (\unicode[STIX]{x1D711}),B_{\unicode[STIX]{x1D711}}=0$
. The components of
 $\mathbf{rot}\,\boldsymbol{B}$
are defined by the determinant:
 $$\begin{eqnarray}\displaystyle \begin{array}{@{}ccc@{}}\displaystyle \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}x} & \displaystyle \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}y} & \displaystyle \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D711}}\\ B_{x} & B_{y} & B_{\unicode[STIX]{x1D711}}\\ \ast & \ast & \ast \end{array}. & & \displaystyle\end{eqnarray}$$
Lemma 2 is proven by the following calculations: at
 $\boldsymbol{x}$
for
 $\boldsymbol{B}_{\text{left}}=\boldsymbol{B}$
(one may assume
 $\unicode[STIX]{x1D711}=\unicode[STIX]{x03C0}/2$
):
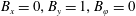 $B_{x}=0,B_{y}=1,B_{\unicode[STIX]{x1D711}}=0$
;
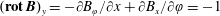 $(\mathbf{rot}\,\boldsymbol{B})_{y}=-\unicode[STIX]{x2202}B_{\unicode[STIX]{x1D711}}/\unicode[STIX]{x2202}x+\unicode[STIX]{x2202}B_{x}/\unicode[STIX]{x2202}\unicode[STIX]{x1D711}=-1$
,
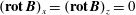 $(\mathbf{rot}\,\boldsymbol{B})_{x}=(\mathbf{rot}\,\boldsymbol{B})_{z}=0$
.
2.4 Eigenfunctions on different manifolds
Consider the spherization of the tangent bundle over the Riemannian sphere
 $\unicode[STIX]{x1D6EC}(S^{2})$
and the spherization of the tangent bundle over the Lobachevskii plane
 $\unicode[STIX]{x1D6EC}(L^{2})$
. The spaces
 $\unicode[STIX]{x1D6EC}(S^{2})$
and
 $\unicode[STIX]{x1D6EC}(L^{2})$
are equipped with the standard Riemannian metrics
 $g_{S}$
and
 $g_{L}$
. The metrics correspond to the standard metrics on
 $S^{2}$
and
 $L^{2}$
and the standard metric on the circle. Denote by
 $\boldsymbol{B}_{\text{left}}$
the magnetic field on
 $(S^{3},g)$
as the pull-back of the magnetic field on
 $\unicode[STIX]{x1D6EC}(S^{2})$
, which is tangent to the geodesic flow. The geodesic magnetic fields on
 $\unicode[STIX]{x1D6EC}(S^{2})$
,
 $\unicode[STIX]{x1D6EC}(L^{2})$
are also denoted by
 $\boldsymbol{B}_{\text{left}}$
.
Lemma 3. The (2.12) is satisfied on
 $(\unicode[STIX]{x1D6EC}(S^{2}),g_{S})$
and
 $(\unicode[STIX]{x1D6EC}(L^{2}),g_{L})$
.
Proof. Let us prove the lemma for the space
 $(\unicode[STIX]{x1D6EC}(S^{2}),g_{S})$
. For the points
 $\hat{\boldsymbol{x}}\in \unicode[STIX]{x1D6EC}(S^{2})$
and
 $\hat{\boldsymbol{y}}\in \unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
in the corresponding neighbourhoods
 $\hat{\boldsymbol{x}}\in \hat{V}_{\hat{\boldsymbol{x}}}\subset \unicode[STIX]{x1D6EC}(S^{2})$
,
 $\hat{\boldsymbol{y}}\in U_{\hat{\boldsymbol{y}}}\subset \unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
, let us construct a mapping
 $\text{pr}:\hat{V}_{\hat{\boldsymbol{x}}}\rightarrow \hat{U} _{\hat{\boldsymbol{y}}}$
, which is an isometry in vertical lines and is a local isometry in horizontal planes up to
 $O(r^{2})$
, where
 $r$
is the distance in
 $U_{\hat{\boldsymbol{x}}}$
.
Consider the natural Riemannian metric
 $g_{S}$
on
 $\unicode[STIX]{x1D6EC}(S^{2})$
in
 $\hat{V}_{\hat{\boldsymbol{x}}}$
locally near a point
 $\hat{\boldsymbol{x}}\in \unicode[STIX]{x1D6EC}(S^{2})$
. In horizontal planes the metric
 $g_{S}$
agrees with the Riemannian metric
 $h$
on the standard sphere
 $S^{2}\subset \mathbb{R}^{3}$
. In vertical planes the metric
 $g_{S}$
corresponds to angles through points on
 $S^{2}$
.
Take a tangent plane
 $T_{\boldsymbol{x}}\subset \mathbb{R}^{3}$
at the point
 $\boldsymbol{x}=p_{1}(\hat{\boldsymbol{x}})\in S^{2}$
, where
 $p_{1}:\unicode[STIX]{x1D6EC}(S^{2})\rightarrow S^{2}$
is the natural projection along vertical coordinates. Consider the stereographic projection
 $P$
from
 $S_{\boldsymbol{x}}^{2}$
into
 $T_{\boldsymbol{x}}$
, which keeps the points:
 $P(\boldsymbol{x})=(\,\boldsymbol{y})$
,
 $\boldsymbol{y}=p_{2}(\,\hat{\boldsymbol{y}})$
,
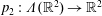 $p_{2}:\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})\rightarrow \mathbb{R}^{2}$
. The projection
 $P$
is a conformal map and is an isometry up to
 $O(r^{2})$
near
 $\boldsymbol{x}$
. This stereographic projection induces the required mapping
 $\text{pr}:\hat{V}_{\boldsymbol{x}}\rightarrow \hat{U} _{\boldsymbol{y}}$
.
From (2.12) for
 $\boldsymbol{B}_{\text{left};\mathbb{R}^{2}}$
on
 $\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
at
 $\boldsymbol{y}$
we get the same equation for
 $P^{\ast }(\boldsymbol{B}_{\text{left};\mathbb{R}^{2}})$
on
 $\unicode[STIX]{x1D6EC}(S^{2})$
at
 $\boldsymbol{x}$
in the induced metric
 $P^{\ast }(g_{S})$
. After we change the metric
 $P^{\ast }(g_{S})$
on
 $\unicode[STIX]{x1D6EC}(S^{2})$
into the natural metric
 $g_{S}$
, we get the same equation for
 $P^{\ast }(\boldsymbol{B}_{\text{left};\mathbb{R}^{2}})$
at
 $\boldsymbol{x}$
, because the curl operator is a first-order operator.
The last required fact is the following:
 $P^{\ast }(\boldsymbol{B}_{\text{left};S^{2}})$
in the standard metric
 $g_{S}$
coincides with the geodesic vector field
 $\boldsymbol{B}_{\text{left}}$
on
 $\unicode[STIX]{x1D6EC}(\mathbb{R}^{2})$
.
To prove the lemma for
 $(\unicode[STIX]{x1D6EC}(L^{2}),g_{L})$
we use analogous arguments: instead of the stereographic projection
 $S^{2}\rightarrow \mathbb{R}^{2}$
, we take a conformal mapping by the identity
 $L^{2}\subset \mathbb{R}^{2}$
, where the Lobachevskii plane
 $L^{2}$
is considered as the Poincarè unit disk on the Euclidean plane. At the central point of the disk the mapping
 $L^{2}\subset \mathbb{R}^{2}$
is an isometry.
Remark 1. Equation (2.3) corresponds with Lemma 3 for
 $\unicode[STIX]{x1D6EC}(S^{2})$
. The natural metric on a Hopf fibre for
 $\unicode[STIX]{x1D6EC}(S^{2})\rightarrow S^{2}$
is proportional to the natural metric of the Hopf fibre for
 $S^{3}\rightarrow S^{2}$
with the coefficient
 $2$
, because
 $S^{3}\rightarrow \unicode[STIX]{x1D6EC}(S^{2})$
is the double covering.
We now generalize the example of Lemma 3 for magnetic fields in domains with non-homogeneous density (volume forms). Let
 $(A,\boldsymbol{x})$
be a complex neighbourhood of a point
 $\boldsymbol{x}$
, equipped with a Riemannian metric
 $g_{A}$
of a constant negative scalar curvature surface. In the example we get
 $A\subset L^{2}$
, where
 $L^{2}$
is the Lobachevskii plane. Let
 $(D,\boldsymbol{y})$
be a complex neighbourhood of a point in the Riemannian sphere
 $S^{2}$
, equipped with the standard Riemannian metric
 $g_{D}$
of a constant positive scalar curvature.
Let
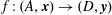 $f:(A,\boldsymbol{x})\rightarrow (D,\boldsymbol{y})$
be a conformal germ of open surfaces
 $A$
and
 $D$
with metrics
 $g_{A}$
,
 $g_{D}$
. Consider the natural extension
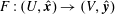 $F:(U,\hat{\boldsymbol{x}})\rightarrow (V,\hat{\boldsymbol{y}})$
of the germ
 $f$
, where
 $\hat{\boldsymbol{x}}\in U\subset \unicode[STIX]{x1D6EC}(A)$
,
 $\hat{\boldsymbol{y}}\in V\subset \unicode[STIX]{x1D6EC}(D)$
are neighbourhoods of points
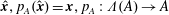 $\hat{\boldsymbol{x}},p_{A}(\hat{\boldsymbol{x}})=\boldsymbol{x},p_{A}:\unicode[STIX]{x1D6EC}(A)\rightarrow A$
,
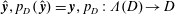 $\hat{\boldsymbol{y}},p_{D}(\,\hat{\boldsymbol{y}})=\boldsymbol{y},p_{D}:\unicode[STIX]{x1D6EC}(D)\rightarrow D$
;
 $U$
,
 $V$
are equipped with the standard Riemannian metrics
 $g_{U}$
and
 $g_{V}$
correspondingly, which are defined using the metrics
 $g_{A}$
and
 $g_{D}$
.
Let us consider an extra copy of
 $U\subset \unicode[STIX]{x1D6EC}(L^{2})$
with an exotic metric, which will be denoted by
 $(\tilde{U} ,h_{\tilde{U} })$
. Define in
 $\tilde{U} \subset \unicode[STIX]{x1D6EC}(L^{2})$
the Riemannian metric
 $h_{\tilde{U} }$
, which coincides with
 $g_{U}$
along horizontal planes
 $A\subset (U,\hat{\boldsymbol{x}})$
of
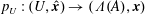 $p_{U}:(U,\hat{\boldsymbol{x}})\rightarrow (\unicode[STIX]{x1D6EC}(A),\boldsymbol{x})$
and coincides with
 $\boldsymbol{k}^{-1}(\boldsymbol{x})g_{U}$
along the vertical fibre of
 $p_{U}$
, where
 $\boldsymbol{k}(\boldsymbol{x})$
is a real positive-valued function, defined by the Jacobian
 $\boldsymbol{k}^{2}(\boldsymbol{x})$
of
 $\text{d}f$
at
 $\boldsymbol{x}$
of the differential
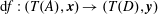 $\text{d}f:(T(A),\boldsymbol{x})\rightarrow (T(D),\boldsymbol{y})$
.
Let us consider an extra copy of
 $V\subset \unicode[STIX]{x1D6EC}(S^{2})$
with an exotic metric, which is denoted by
 $(\tilde{V},h_{\tilde{V}})$
. Define in
 $\tilde{V}\subset \unicode[STIX]{x1D6EC}(S^{2})$
the Riemannian metric
 $h_{\tilde{V}}$
that coincides with
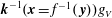 $\boldsymbol{k}^{-1}(\boldsymbol{x}=f^{-1}(\,\boldsymbol{y}))g_{V}$
.
Let
 $\bar{V}\rightarrow V$
,
 $\bar{V}\subset S^{3}$
, be the natural double covering, which is the isometry on horizontal planes and is the multiplication by
 $2$
in each of the vertical circle fibres of the standard projection
 $p:S^{3}\rightarrow \unicode[STIX]{x1D6EC}(S^{2})$
. Define in
 $\bar{V}$
a Riemannian metric
 $g_{\bar{V}}$
that coincides with
 $g_{V}$
along horizontal planes and with
 $g_{V}/2$
along vertical fibres.
The Riemannian metrics
 $g_{U}$
,
 $h_{\tilde{U} }$
,
 $h_{\tilde{V}}$
,
 $g_{V}$
and
 $g_{\bar{V}}$
determine the volume 3-forms
 $\text{d}U$
(the standard form in
 $\unicode[STIX]{x1D6EC}(L^{2})$
),
 $\text{d}\tilde{U}$
,
 $\text{d}\tilde{V}$
,
 $\text{d}V$
(the standard form in
 $\unicode[STIX]{x1D6EC}(S^{2})$
) and
 $\text{d}\bar{V}$
(the standard form in
 $S^{3}$
) in
 $U$
,
 $\tilde{U}$
,
 $\tilde{V}$
,
 $V$
and
 $\bar{V}$
respectively. Recall
 $A\subset L^{2}$
with the standard 2-volume form
 $\text{d}L$
on the Lobachevskii plane. The volume form
 $\text{d}\tilde{U}$
is defined by
 $\text{d}\tilde{U} =\boldsymbol{k}(\boldsymbol{x})\text{d}U$
, where
 $\text{d}U$
is the standard volume form in
 $U$
, which is the product of the horizontal standard 2-form
 $\text{d}L$
on the Lobachevskii plane with the standard vertical 1-form on the circle. Analogously,
 $\text{d}\tilde{V}=\boldsymbol{k}^{-2}(\,\boldsymbol{y})\text{d}V$
, where
 $\text{d}V$
is the standard volume form on
 $V=\tilde{V}\subset \unicode[STIX]{x1D6EC}(S^{2})$
. The volume forms
 $\text{d}V$
,
 $\text{d}\bar{V}$
coincide with the standard volume forms (
 $\text{d}V$
is the restriction of the standard volume form on
 $\unicode[STIX]{x1D6EC}(S^{2})$
,
 $\text{d}\bar{V}$
is the restriction of the standard volume form on
 $S^{3}$
;
 $\text{d}\bar{V}=2p^{\ast }\text{d}V$
, where
 $\bar{V}$
is standardly identified with
 $V$
by
 $p:\bar{V}\rightarrow V$
). The volume forms
 $\text{d}V$
,
 $\text{d}\bar{V}$
are equipped with the density functions
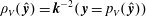 $\unicode[STIX]{x1D70C}_{V}(\,\hat{\boldsymbol{y}})=\boldsymbol{k}^{-2}(\,\boldsymbol{y}=p_{V}(\,\hat{\boldsymbol{y}}))$
,
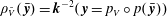 $\unicode[STIX]{x1D70C}_{\bar{V}}(\,\bar{\boldsymbol{y}})=\boldsymbol{k}^{-2}(\,\boldsymbol{y}=p_{V}\circ p(\,\bar{\boldsymbol{y}}))$
.
Let
 $\boldsymbol{B}_{U}$
be the magnetic field (horizontal) in
 $U$
with the metric
 $g_{U}$
, which is defined by the geodesic flows in
 $A$
with the metric
 $g_{A}$
. Define the magnetic field
 $\boldsymbol{B}_{\text{left};\tilde{U} }$
in
 $\tilde{U}$
with the metric
 $h_{\tilde{U} }$
by
 $\boldsymbol{B}_{\text{left};\tilde{U} }=\boldsymbol{B}_{U}$
.
By construction, the metrics
 $h_{\tilde{U} }$
and
 $h_{\tilde{V}}$
agree (are isometric):
 $F_{\ast }(h_{\tilde{U} })=h_{\tilde{V}}$
. Denote by
 $\boldsymbol{B}_{\text{left};\tilde{V}}$
the magnetic field
 $F_{\ast }(\boldsymbol{B}_{\text{leftU};\tilde{U} })$
in
 $\tilde{V}\subset \unicode[STIX]{x1D6EC}(S^{2})$
with the metric
 $h_{\tilde{V}}$
. Denote by
 $\boldsymbol{B}_{\text{left};V}$
the magnetic field
 $\boldsymbol{k}^{-3}(\,\hat{\boldsymbol{y}})\boldsymbol{B}_{\text{left};\tilde{V}}$
in
 $V\subset \unicode[STIX]{x1D6EC}(S^{2})$
with the standard metric
 $g_{V}$
and with the variable density
 $\unicode[STIX]{x1D70C}_{V}(\,\hat{\boldsymbol{y}})$
. Denote by
 $\boldsymbol{B}_{\text{left}\bar{V}}^{S3}$
the magnetic field
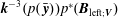 $\boldsymbol{k}^{-3}(p(\,\bar{\boldsymbol{y}}))p^{\ast }(\boldsymbol{B}_{\text{left};\boldsymbol{V}})$
in
 $\bar{V}\subset S^{3}$
with the standard spherical metric
 $g_{\bar{V}}$
and with the variable density
 $\unicode[STIX]{x1D70C}_{\bar{V}}(\,\bar{\boldsymbol{y}})$
.
Lemma 4.
(i) In the domain
 $\tilde{U}$
the following equation is satisfied: (2.14)where$$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \mathbf{div}(\boldsymbol{B}_{\text{left};\tilde{U} })=0;\quad \mathbf{rot}\,\boldsymbol{B}_{\text{left};\tilde{U} }(\hat{\boldsymbol{x}})=-\boldsymbol{k}(\boldsymbol{x})\boldsymbol{B}_{\text{left};\tilde{U} }(\hat{\boldsymbol{x}}),\\ \displaystyle \hat{\boldsymbol{x}}\in \tilde{U} ,\quad \boldsymbol{x}=p_{\tilde{U} }(\hat{\boldsymbol{x}})\in A,\end{array}\right\} & & \displaystyle\end{eqnarray}$$
$\mathbf{rot}$
and
$\mathbf{div}$
are defined for the Riemannian metric
$h_{\tilde{U} }$
with the density
$\unicode[STIX]{x1D70C}_{U}(\hat{\boldsymbol{x}})$
.
(ii) In the domain
$V\subset \unicode[STIX]{x1D6EC}(S^{2})$
the following equation is satisfied: (2.15)where$$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \mathbf{div}(\boldsymbol{B}_{\text{left};V}(\,\hat{\boldsymbol{y}}))=0;\quad \mathbf{rot}\,\boldsymbol{B}_{\text{left};V}(\,\hat{\boldsymbol{y}})=-\boldsymbol{B}_{\text{left};V}(\,\hat{\boldsymbol{y}}),\\ \displaystyle \hat{\boldsymbol{y}}\in V,\quad \boldsymbol{y}=p_{V}(\,\hat{\boldsymbol{y}})\in D,\end{array}\right\} & & \displaystyle\end{eqnarray}$$
$\mathbf{rot}$
is defined for the standard Riemannian metric
$g_{V}$
with the density
$\unicode[STIX]{x1D70C}_{V}(\,\hat{\boldsymbol{y}})$
.(iii) In the domain
$\bar{V}\subset S^{3}$
the following equation is satisfied: (2.16)where$$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \mathbf{div}(\boldsymbol{B}_{\text{left};\bar{V}}(\,\bar{\boldsymbol{y}}))=0;\quad \mathbf{rot}\,\boldsymbol{B}_{\text{left};\bar{V}}(\,\hat{\boldsymbol{y}})=-2\boldsymbol{B}_{\text{left};\bar{V}}(\,\hat{\boldsymbol{y}}),\\ \displaystyle \bar{\boldsymbol{y}}\in \bar{V},\quad \boldsymbol{y}=p_{V}\circ p(\,\bar{\boldsymbol{y}})\in D,\end{array}\right\} & & \displaystyle\end{eqnarray}$$
$\mathbf{rot}$
is defined for the standard spherical Riemannian metric
$g_{\bar{V}}$
with the density
$\unicode[STIX]{x1D70C}_{\bar{V}}(\,\bar{\boldsymbol{y}})$
.


Proof. By construction, the magnetic field
 $\boldsymbol{B}_{U}$
satisfies (2.10) in
 $U$
. The transformation from
 $U$
to
 $\tilde{U}$
is the identity, but not isometry. The first (2.14) is satisfied, because the volume form in
 $U$
corresponds with the metric
 $h_{\tilde{U} }$
. The transformation
 $\boldsymbol{B}_{U}\mapsto \boldsymbol{B}_{\text{left};\tilde{U} }$
is frozen in and keeps the magnetic flow. The second (2.14) is satisfied, because the metric
 $h_{\tilde{U} }$
is constant in vertical fibres and the factor
 $\boldsymbol{k}(\boldsymbol{x})$
on the right-hand side of the equation corresponds to the partial derivatives along the vertical coordinates. This proves (2.14).
The transformation
 $\boldsymbol{B}_{\text{left};\tilde{U} }\mapsto \boldsymbol{B}_{\text{left};V}$
is decomposed into transformations
 $$\begin{eqnarray}\boldsymbol{B}_{\text{left};\tilde{U} }\mapsto \boldsymbol{B}_{\text{left};\tilde{V}}\mapsto \boldsymbol{B}_{\text{left};V}.\end{eqnarray}$$
The transformation
 $\boldsymbol{B}_{\text{left};\tilde{U} }\mapsto \boldsymbol{B}_{\text{left};\tilde{V}}$
is an isometry and
 $\boldsymbol{B}_{\text{left};\tilde{V}}$
satisfies (2.14) in
 $\tilde{V}$
. The transformation
 $\boldsymbol{B}_{\text{left};\tilde{V}}\mapsto \boldsymbol{B}_{\text{left};V}$
is conform with the scalar factor
 $\boldsymbol{k}(\,\boldsymbol{y})$
. This transformation changes (2.14) in
 $\tilde{V}$
into (2.15) in
 $V$
with non-uniform density.
The calculations for this transformation are as follows. Take a domain
 $\tilde{V}$
with local coordinates
 $\hat{\boldsymbol{x}}=(x,y,z)$
. Take a transformation
 $g\mapsto \unicode[STIX]{x1D706}g$
of the metric in
 $\tilde{V}$
into a metric in
 $V$
with a scale
 $\unicode[STIX]{x1D706}(\hat{\boldsymbol{x}})>0$
. The following transformation of coordinates
 $x\mapsto \unicode[STIX]{x1D706}x_{1}$
,
 $y\mapsto \unicode[STIX]{x1D706}y_{1}$
,
 $z\mapsto \unicode[STIX]{x1D706}z_{1}$
is an isometric transformation of
 $(\tilde{V},g)$
into
 $(V,\unicode[STIX]{x1D706}g)$
, where
 $\hat{\boldsymbol{x}}_{1}=(x_{1},y_{1},z_{1})$
are the coordinates in
 $V$
. Before the transformation we get a differential
 $1$
-form
 $\unicode[STIX]{x1D6FD}\text{d}z$
which is by assumption, a proper form of the operator
 $\ast \circ d$
with a proper function
 $-\unicode[STIX]{x1D706}(\boldsymbol{x})$
(see (2.9) with analogous calculations) in
 $\tilde{V}$
. This implies
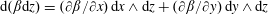 $\text{d}(\unicode[STIX]{x1D6FD}\text{d}z)=(\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}/\unicode[STIX]{x2202}x)\,\text{d}x\wedge \text{d}z+(\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}/\unicode[STIX]{x2202}y)\,\text{d}y\wedge \text{d}z$
;
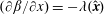 $(\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}/\unicode[STIX]{x2202}x)=-\unicode[STIX]{x1D706}(\hat{\boldsymbol{x}})$
,
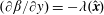 $(\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}/\unicode[STIX]{x2202}y)=-\unicode[STIX]{x1D706}(\hat{\boldsymbol{x}})$
. After the transformation we get the
 $1$
-form
 $\unicode[STIX]{x1D706}\unicode[STIX]{x1D6FD}\text{d}z_{1}$
. We have:
 $$\begin{eqnarray}\left.\begin{array}{@{}rcl@{}}\displaystyle \text{d}(\unicode[STIX]{x1D706}\unicode[STIX]{x1D6FD}\,\text{d}z_{1})\; & =\; & \displaystyle \frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}}{\unicode[STIX]{x2202}x}\unicode[STIX]{x1D706}\,\text{d}x\wedge \text{d}z_{1}+\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}}{\unicode[STIX]{x2202}y}\unicode[STIX]{x1D706}\,\text{d}y\wedge \text{d}z_{1}+\frac{\unicode[STIX]{x1D6FD}}{\unicode[STIX]{x1D706}}\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D706}}{\unicode[STIX]{x2202}x}\,\text{d}x_{1}\wedge \text{d}z_{1}+\frac{\unicode[STIX]{x1D6FD}}{\unicode[STIX]{x1D706}}\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D706}}{\unicode[STIX]{x2202}y}\,\text{d}y_{1}\wedge \text{d}z_{1}\\ \; & \; & +\,\displaystyle \unicode[STIX]{x1D706}\unicode[STIX]{x1D6FD}\,\text{d}x\wedge \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}x}\left(\frac{1}{\unicode[STIX]{x1D706}}\,\text{d}z\right)+\unicode[STIX]{x1D706}\unicode[STIX]{x1D6FD}\,\text{d}y\wedge \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}x}\left(\frac{1}{\unicode[STIX]{x1D706}}\,\text{d}z\right).\end{array}\right\}\end{eqnarray}$$
Using
 $\unicode[STIX]{x2202}/\unicode[STIX]{x2202}z_{1}=\unicode[STIX]{x1D706}(\unicode[STIX]{x2202}/\unicode[STIX]{x2202}z)$
,
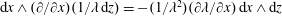 $\text{d}x\wedge (\unicode[STIX]{x2202}/\unicode[STIX]{x2202}x)(1/\unicode[STIX]{x1D706}\,\text{d}z)=-(1/\unicode[STIX]{x1D706}^{2})(\unicode[STIX]{x2202}\unicode[STIX]{x1D706}/\unicode[STIX]{x2202}x)\,\text{d}x\wedge \text{d}z$
,
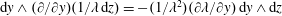 $\text{d}y\wedge (\unicode[STIX]{x2202}/\unicode[STIX]{x2202}y)(1/\unicode[STIX]{x1D706}\,\text{d}z)=-(1/\unicode[STIX]{x1D706}^{2})(\unicode[STIX]{x2202}\unicode[STIX]{x1D706}/\unicode[STIX]{x2202}y)\,\text{d}y\wedge \text{d}z$
, we have:
 $$\begin{eqnarray}\left.\begin{array}{@{}rcl@{}}\displaystyle \text{d}(\unicode[STIX]{x1D706}\unicode[STIX]{x1D6FD}\,\text{d}z_{1})\; & =\; & \displaystyle \frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}}{\unicode[STIX]{x2202}x}\unicode[STIX]{x1D706}\,\text{d}x\wedge \text{d}z_{1}+\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}}{\unicode[STIX]{x2202}y}\unicode[STIX]{x1D706}\,\text{d}y\wedge \text{d}z_{1}=\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}}{\unicode[STIX]{x2202}x}\,\text{d}x_{1}\wedge \text{d}z_{1}+\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6FD}}{\unicode[STIX]{x2202}y}\,\text{d}y_{1}\wedge \text{d}z_{1}\\ \; & =\; & \displaystyle -\unicode[STIX]{x1D706}(\text{d}x_{1}\wedge \text{d}z_{1}+\text{d}y_{1}\wedge \text{d}z_{1}).\end{array}\right\}\end{eqnarray}$$
This proves that
 $\unicode[STIX]{x1D706}\unicode[STIX]{x1D6FD}\text{d}z_{1}$
is the proper
 $1$
-form of the operator
 $\ast \circ \text{d}$
in
 $V$
with the proper function
 $-\unicode[STIX]{x1D706}^{-1}\unicode[STIX]{x1D706}=-1$
. Setting
 $\boldsymbol{k}(\boldsymbol{x})=\unicode[STIX]{x1D706}(\boldsymbol{x})$
, we get the required formula (2.15).
The transformation
 $\boldsymbol{B}_{\text{left};V}\mapsto \boldsymbol{B}_{\text{left};\bar{V}}$
is analogous to the transformation
 $\boldsymbol{B}_{U}\mapsto \boldsymbol{B}_{\text{left};\tilde{U} }$
. In this transformation
 $\boldsymbol{B}_{\text{left}}$
is frozen in and the scalar factor
 $2$
on the right-hand side of the second equation (2.16) corresponds to the transformation of the metrics
 $g_{V}\mapsto g_{\bar{V}}$
, which changes partial derivatives along the vertical coordinate.
3 Magnetic force-free configurations on non-homogeneous
$S^{3}$

Let
 $P\subset L^{2}$
be the right
 $k$
-triangle (all
 $k$
-vertices on the absolute) on the Lobachevskii plane. Let
 $f_{k}:P\rightarrow S_{+}^{2}$
be the conformal transformation (the Picard analytic function in the case
 $k=3$
) of the square (
 $k$
-angle) onto the upper hemisphere of the Riemannian sphere
 $S^{2}$
. The vertices
 $v_{1},v_{2},\ldots ,v_{k}$
of
 $P$
are mapped into points
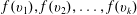 $f(v_{1}),f(v_{2}),\ldots ,f(v_{k})$
at the equator
 $S^{1}\subset S^{2}$
and we assume that
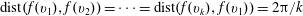 $\text{dist}(f(v_{1}),f(v_{2}))=\cdots =\text{dist}(f(v_{k}),f(v_{1}))=2\unicode[STIX]{x03C0}/k$
. Denote by
 $f:L^{2}\rightarrow S^{2}$
the branched cover with ramifications at
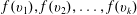 $f(v_{1}),f(v_{2}),\ldots ,f(v_{k})$
, which is defined as the conformal periodic extension of
 $f_{k}$
on the Lobachevskii plane. It is well known that
 $\unicode[STIX]{x1D6EC}(S^{2})=S^{3}/-1$
, where on the right-hand side of the formula is the quotient of the standard
 $3$
-sphere by the antipodal involution. The fibre of
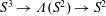 $S^{3}\rightarrow \unicode[STIX]{x1D6EC}(S^{2})\rightarrow S^{2}$
over the points
 $f(v_{1}),\ldots f(v_{k})$
in the base is the Hopf
 $k$
-component link, which is denoted by
 $l\subset S^{3}$
. For
 $k=3$
link
 $l$
consists of 3 big circles, each two circles are linked with the coefficient
 $+1$
, denote the Jacobian of
 $f$
by
 $\boldsymbol{k}^{2}(\boldsymbol{x})$
,
 $\boldsymbol{x}\in P$
,
 $\boldsymbol{y}=f(\boldsymbol{x})\in S^{2}$
. Statement (i) of the following lemma is a corollary from Lemma 4.
Theorem 1. Assume
 $k\geqslant 3$
is fixed.
(i) For magnetic force-free field
$\boldsymbol{B}_{\text{left}}$
on
$S^{3}\setminus l$
with the standard Riemannian metric
$g$
and the density function
$\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})=\boldsymbol{k}^{-2}(\,\boldsymbol{y})$
,
$\boldsymbol{y}=p(\,\hat{\boldsymbol{y}})$
, with the standard Hopf bundle
$p:S^{3}\rightarrow S^{2}\rightarrow \unicode[STIX]{x1D6EC}(S^{2})$
, there are
$k$
-component exceptional fibres
$l\subset S^{3}$
with an infinite density.(ii) The
$k$
-component pinch curve
$l$
of the magnetic field
$\boldsymbol{B}_{\text{left}}$
is the standard
$k$
-component Hopf link in
$S^{3}$
. The components of
$l$
are preimages of points
$f(v_{1}),f(v_{2}),\ldots ,f(v_{k})$
by the projection
$p:S^{3}\rightarrow \unicode[STIX]{x1D6EC}(S^{2})$
.(iii) In the case
$k=3$
the scalar factor of the density function
$\sqrt{\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})}=\boldsymbol{k}^{-1}(\,\boldsymbol{y})$
in (2.14) has an asymptotic
$(-z\ln (z))^{-1}$
near
$l$
, where
$z$
is the distance from
$\hat{\boldsymbol{y}}$
to
$l$
. The magnetic field has the asymptotic
$(-z\ln (z))^{-1}$
for
$z\rightarrow 0+$
. The magnetic energy
$\int B^{2}~\text{d}\unicode[STIX]{x1D6FA}$
, where
$B^{2}(\,\hat{\boldsymbol{y}})=\boldsymbol{k}^{-2}(\,\hat{\boldsymbol{y}})$
and
$\hat{\boldsymbol{y}}\in \unicode[STIX]{x1D6FA}=S^{3}\setminus l$
, has the asymptotic
$\simeq \int _{0}^{+\unicode[STIX]{x1D700}}(z\ln ^{2}(z))^{-1}~\text{d}z<+\infty$
near a component of a cusp curve
$l$
, in the standard metric on
$S^{3}$
.(iv) In the case
$k=3$
,
$\boldsymbol{B}_{\text{left};3}$
is projected to tangents along trajectories of the Lorenz attractor (Ghys & Leys Reference Ghys and Leys2006; Dehornoy Reference Dehornoy2015) by a 12-sheeted branching covering
$S^{3}\setminus l\rightarrow S^{3}\setminus l^{\prime }$
, which transforms
$l$
into the exceptional trefoil
$l^{\prime }$
of the Lorenz attractor.(v) The stereographic projection
$S^{3}\setminus pt\rightarrow \mathbb{R}^{3}$
transforms
$\boldsymbol{B}_{\text{left}}$
into a force-free magnetic field with a finite magnetic energy in non-homogeneous isotropic space
$\mathbb{R}^{3}$
. This construction is analogous to Kamchatnov (Reference Kamchatnov1982).


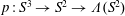


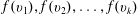


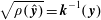


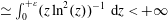


Proof. [(iii)] Let
 $H^{\uparrow }$
be the upper half-plane with the complex coordinate, denoted by
 $w$
,
 $H^{\uparrow }\equiv L$
, where
 $L$
is the Lobachevskii plane, equipped with the standard conformal metric,
 $H^{\downarrow }$
be the lower half-plane,
 $H_{+}$
be the right half-plane
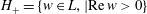 $H_{+}=\{w\in L,|\text{Re}\,w>0\}$
and
 $H_{-}$
be the left half-plane. We identify
 $H^{\downarrow }$
with the Lobachevskii plane
 $L$
,
 $H_{-}$
with the Riemannian half-sphere. Let
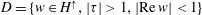 $D=\{w\in H^{\uparrow },|\unicode[STIX]{x1D70F}|>1,|\text{Re}\,w|<1\}$
be the triangle in
 $H^{\uparrow }$
. Let us consider the analytic function
 $F:D\rightarrow H_{+}$
,
 $F(\infty )=\infty$
,
 $F(+1)=\boldsymbol{i}$
,
 $F(-1)=-\boldsymbol{i}$
. From the conditions we get
 $F(\boldsymbol{i})=0$
.
Take the triangle
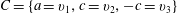 $C=\{a=v_{1},c=v_{2},-c=v_{3}\}$
on
 $H^{\downarrow }$
,
 $a=0,c=+1$
. The considered triangle is mapped onto the triangle
 $D=\{\infty ,c,-c\}$
in the upper half-plane
 $H^{\uparrow }$
by
 $I_{1}:x\mapsto x^{-1}=w$
(see figure 2).
The function
 $f:C\rightarrow H_{-}$
is the composition of the maps
 $I_{1}:x\mapsto x^{-1}=w$
,
 $F:D\rightarrow H^{+}$
,
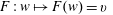 $F:w\mapsto F(w)=v$
,
 $I_{2}:H_{+}\rightarrow H_{-}$
,
 $I_{2}:v\mapsto v^{-1}=y$
;
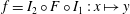 $f=I_{2}\circ F\circ I_{1}:x\mapsto y$
. The function
 $F$
is called the modular function, this function has the asymptotic
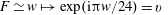 $F\simeq w\mapsto \exp (\text{i}\unicode[STIX]{x03C0}w/24)=v$
, when
 $w\rightarrow +\boldsymbol{i}\infty$
. The goal is to calculate the scalar factor
 $\boldsymbol{k}$
near the origin
 $f(0)=0$
in the target domain.
In
 $C\subset H^{\downarrow }$
we get the metric on the hyperbolic plane, near the origin on the boundary. The distance between two points on a vertical ray is given by the logarithmic scale. In
 $H_{-}$
near the origin the metric is the Euclidean metric.
We get:
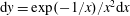 $\text{d}y=\exp (-1/x)/x^{2}\text{d}x$
and
 $\text{d}x/x=\text{d}l$
, where
 $l$
the distance in the domain space,
 $x$
is the Euclidean coordinate in the domain space,
 $y$
is the coordinate in the target space, which corresponds to the metric. Therefore, the scalar factor
 $\boldsymbol{k}^{-1}(\,\hat{\boldsymbol{y}})$
depends of the distance
 $z$
from the cusp
 $L$
in the target space
 $S^{3}$
with the standard metric as follows:
 $$\begin{eqnarray}\boldsymbol{k}(z)\approx -z\ln (z).\end{eqnarray}$$
By this asymptotic we get the asymptotic of the magnetic energy is given by the prescribed integral over
 $z$
.
Proof. [(ii), (iv)] The Lorenz attractor by Ghys & Leys (Reference Ghys and Leys2006) coincides with the geodesic flows on the orbifold
 $(2,3,\infty )$
from Dehornoy (Reference Dehornoy2015). The spherization of the tangent bundle over the orbifold
 $(2,3,\infty )$
, which is the space of the geodesic flow, is an open manifold diffeomorphic to the complement of the trefoil in the
 $3$
-sphere
 $S^{3}\setminus l^{\prime }$
. The orbifold
 $(2,3,\infty )$
is the quotient of the Lobachevskii plane by the corresponding Fuchsian group. The fundamental domain
 $P^{\prime }$
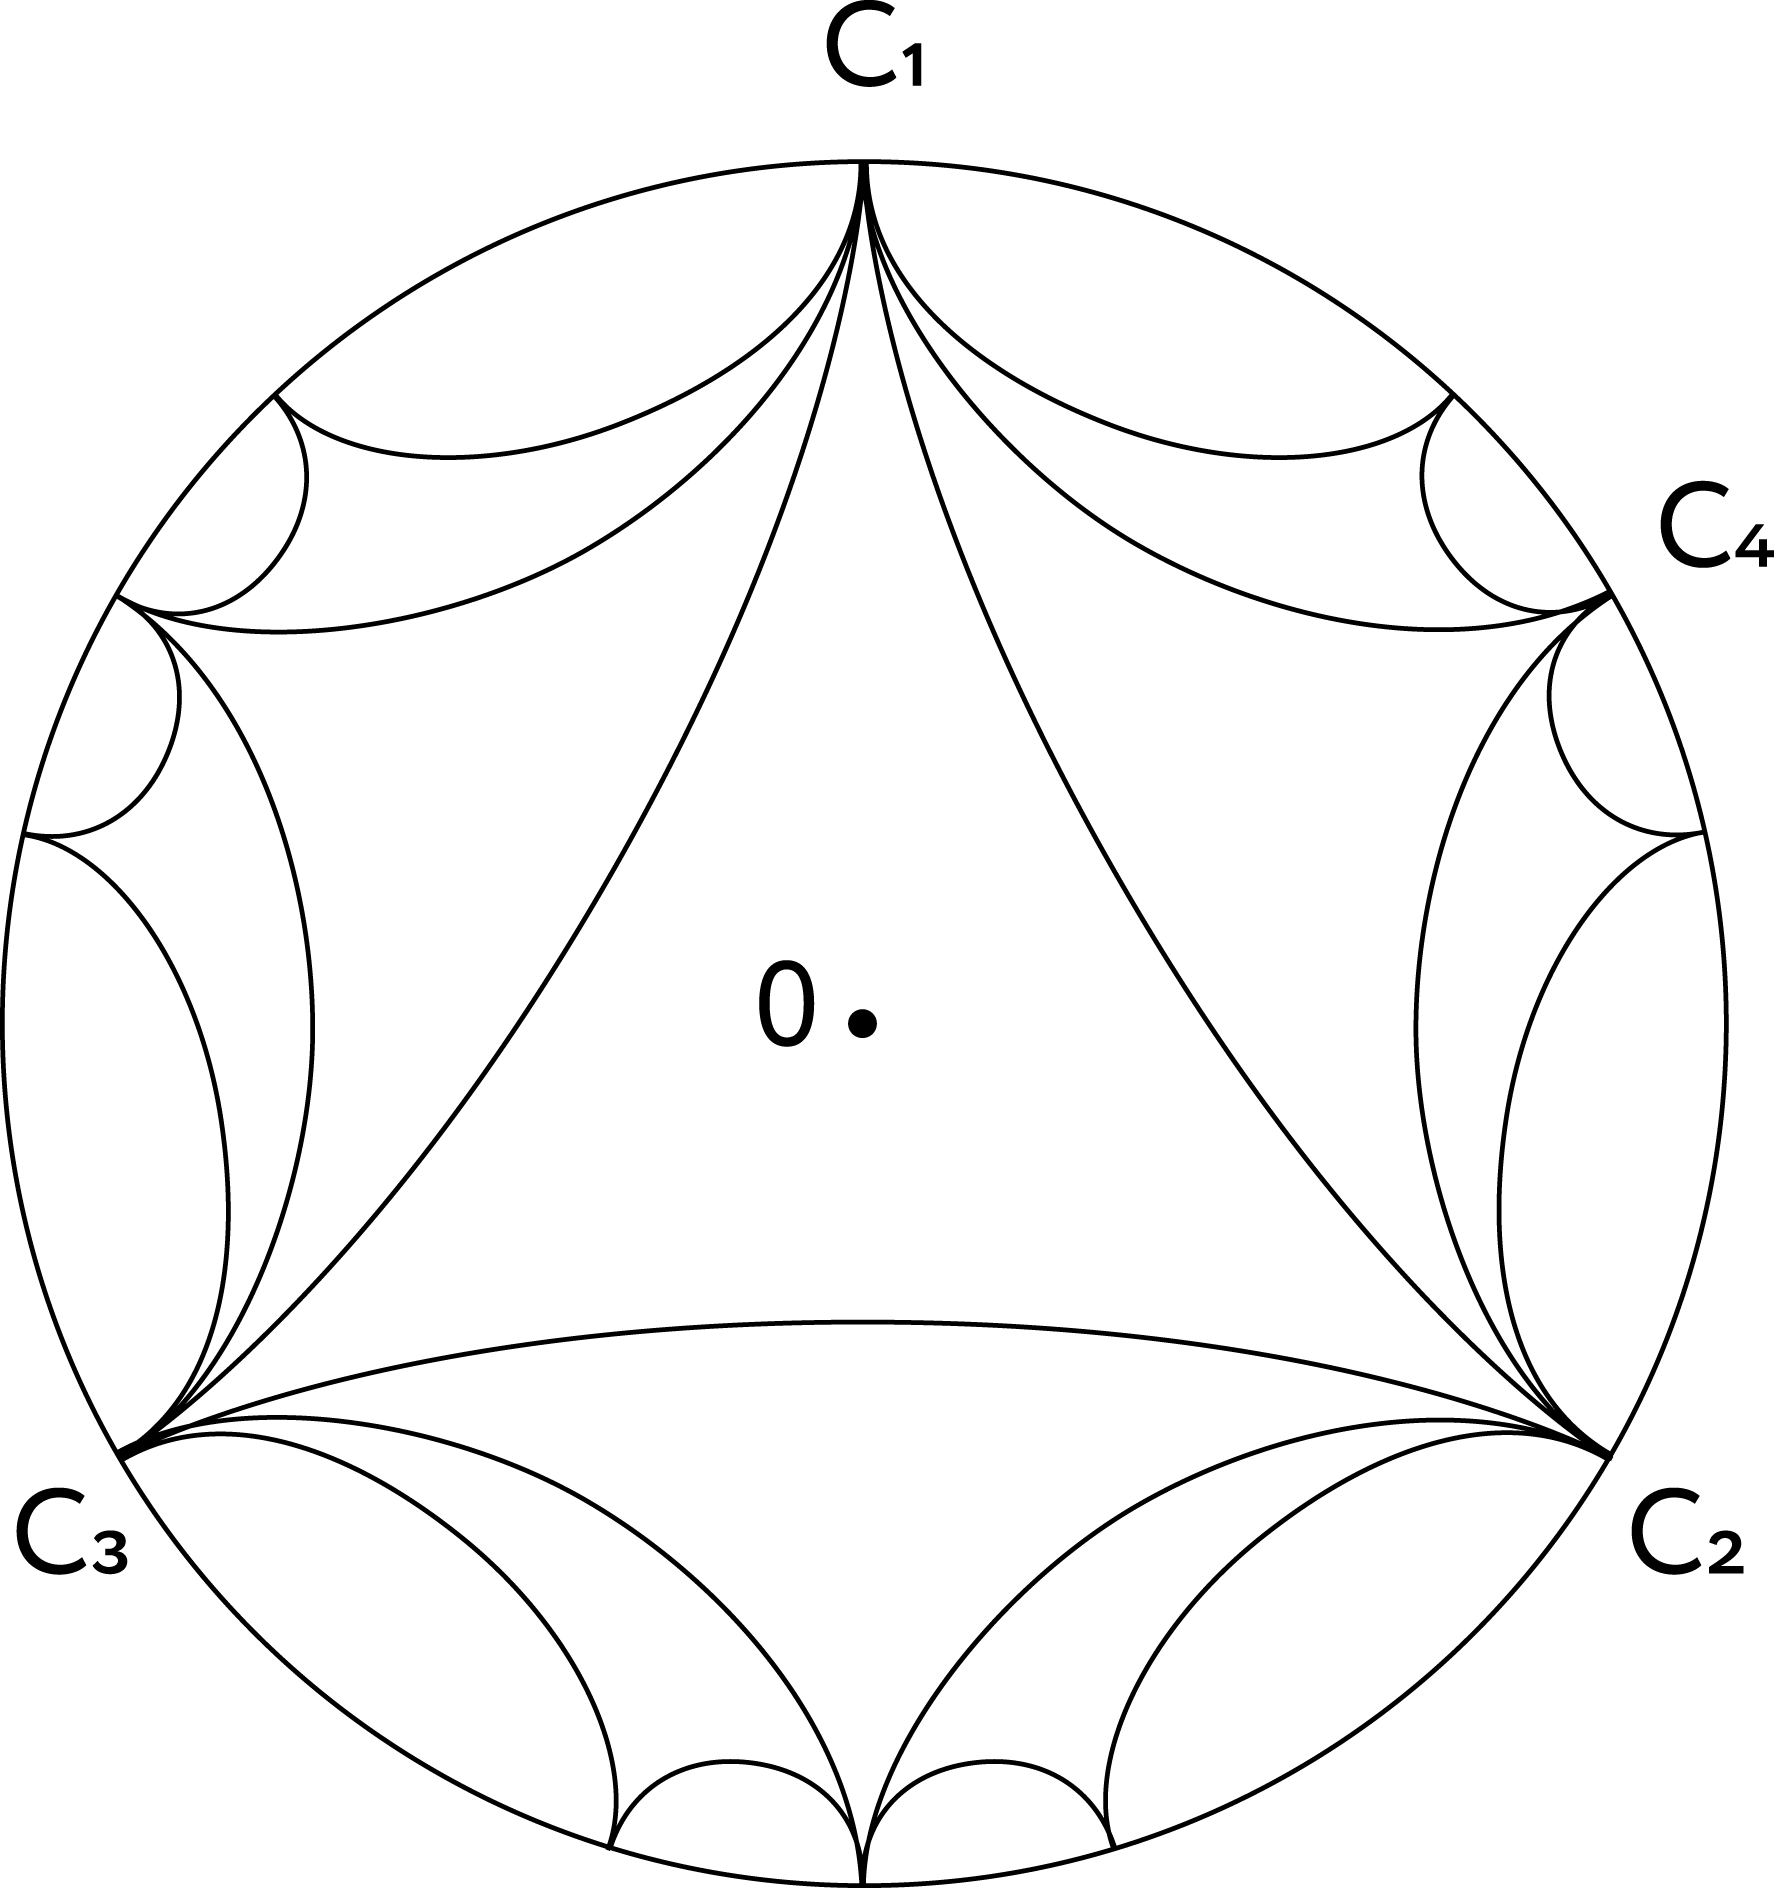
of this orbifold is the triangle
 $\triangle OC_{1}C_{2}$
with angles
 $(\unicode[STIX]{x03C0}/3,0,0)$
. This triangle is contained as a
 $1/3$
-triangle in the triangle
 $P=\triangle C_{1}C_{2}C_{3}$
with the angles
 $(0,0,0)$
with the vertex on the absolute (see figure 3). The fundamental domain
 $Q$
of the magnetic force-free field
 $\boldsymbol{B}_{\text{left}}$
for
 $k=3$
is the 2-sheet covering over the space of
 $S^{1}$
-fibration over the union
 $P\cup P_{1}$
of 2 triangles
 $P=\triangle C_{1}C_{2}C_{3}$
,
 $P_{1}=\triangle C_{2}C_{3}C_{4}$
, which are identified along the fibration over the common edge
 $(C_{2}C_{3})$
. Therefore, the fundamental domain
 $Q$
is a
 $6$
-sheeted covering space over
 $\unicode[STIX]{x1D6EC}(P^{\prime })$
.
The covering over the orbifold
 $(2,3,\infty )$
for the Lorenz attractor. The point
 $C_{4}$
is the image of
 $C_{3}$
with respect to the central symmetry over the fold point on
 $(C_{1},C_{2})$
.

According to Ghys & Leys (Reference Ghys and Leys2006), the spherization of the tangent bundle
 $\unicode[STIX]{x1D6EC}(P^{\prime })$
over the fundamental domain
 $P^{\prime }$
is diffeomorphic to
 $S^{3}\setminus l^{\prime }$
, where
 $l^{\prime }$
is the exceptional fibre (the trefoil), which corresponds to the vertex of the domain
 $P^{\prime }$
, the vertex are identified by an action of the Fuchsian group. By the construction the spherization of the tangent bundle
 $\unicode[STIX]{x1D6EC}(P\cup P_{1})$
over the fundamental domain
 $P\cup P_{1}$
is diffeomorphic to
 $\unicode[STIX]{x1D6EC}(S^{2})\setminus l^{\prime \prime }$
,
 $S^{3}/-1=\unicode[STIX]{x1D6EC}(S^{2})$
, where
 $l^{\prime \prime }$
is the union of 3 exceptional fibres, which are correspondent to the vertex
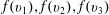 $f(v_{1}),f(v_{2}),f(v_{3})$
of the
 $1/2$
-fundamental domain
 $P$
. This proves that
 $\unicode[STIX]{x1D6EC}(S^{2})\setminus l^{\prime \prime }$
is a
 $6$
-covering space over
 $S^{3}\setminus l^{\prime }$
, which is branched over the trefoil
 $l^{\prime }$
.
A neighbourhood of the exceptional trefoil
 $l^{\prime }$
in the Lorenz attractor is covered by a non-connected neighbourhood of
 $l^{\prime \prime }\subset S^{3}/-1$
, which is the standard 3-Hopf link. An extra
 $2$
-covering
 $S^{3}\rightarrow \unicode[STIX]{x1D6EC}(S^{2})$
determines the required
 $12$
covering
 $S^{3}\setminus l\rightarrow S^{3}\setminus l^{\prime }$
, which is also branched over the trefoil
 $l^{\prime }$
.
Remark 2. By Theorem 1, (iii) the magnetic field
 $\boldsymbol{B}_{\text{left}}$
on
 $S^{3}\setminus l$
is compactified into the magnetic field on
 $S^{3}$
, which tends to infinity on
 $l\subset S^{3}$
. The magnetic field
 $\boldsymbol{B}_{\text{left}}$
is an
 $Z_{6}$
-equivariant with respect to the standard action
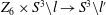 $Z_{6}\times S^{3}\setminus l\rightarrow S^{3}\setminus l^{\prime }$
of the cyclic group of the order
 $6$
, therefore the magnetic field
 $\hat{\boldsymbol{B}}_{\text{left}}$
on the lens quotient
 $\hat{Q}=(S^{3}\setminus l)/Z_{6}$
is well defined. The domain
 $\hat{Q}$
with magnetic field is a covering space over the domain with the Lorenz attractor in
 $S^{3}$
, over the exceptional fibre
 $l^{\prime }\subset S^{3}$
the covering is ramified.
4 MHD solitons
By MHD solitons we mean quasi-stationary solutions of the ideal MHD equations. An example of MHD soliton was discovered by Kamchatnov (Reference Kamchatnov1982) and generalized by Semenov et al. (Reference Semenov, Korovinski and Biernat2002). For these examples the velocity field is parallel to the magnetic field. We shall define analogous examples of solitons in
 $S^{3}$
, where the velocity field is perpendicular to the magnetic field. Example 1 is constructed by means of the Hopf magnetic field. Example 2 is a hyperbolic analogue, constructed using a force-free magnetic field from § 3. This hyperbolic soliton is defined in a non-homogeneous
 $S^{3}$
with pinches. The velocity field is perpendicular to the gradient of the density function
 $\unicode[STIX]{x1D70C}$
. This means that the density function does not depend on time.
We consider MHD solitons for the sphere
 $S^{3}$
with the standard metric
 $g$
with constant and variable density
 $\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})$
,
 $\hat{\boldsymbol{y}}\in S^{3}$
, see Arnol’d & Khesin (Reference Arnol’d and Khesin2013) Remark 1.6 p. 262 and Remark 1.1 p. 120, for the MHD-equations on a Riemannian manifold. The density positive function
 $\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})$
is equivalent so that the standard metric
 $g$
is changed
 $g\mapsto \unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})^{-1/3}g$
by a conformal transformation.
A quasi-stationary solution means that the velocity field
 $\boldsymbol{v}$
does not depend on time (see (4.2)).
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}\boldsymbol{B}}{\unicode[STIX]{x2202}t}=-\{\boldsymbol{v},\boldsymbol{B}\}, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}\boldsymbol{v}}{\unicode[STIX]{x2202}t}=-(\boldsymbol{v},\unicode[STIX]{x1D735})\boldsymbol{v}+\mathbf{rot}\,\boldsymbol{B}\times \boldsymbol{B}-\mathbf{grad}\,p, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \mathbf{div}(\boldsymbol{B})=\mathbf{div}(\boldsymbol{v})=0. & \displaystyle\end{eqnarray}$$
Example 1. Assume that the standard
 $S^{3}$
is homogeneous:
 $\unicode[STIX]{x1D70C}\equiv 1$
. Define
 $\boldsymbol{v}=\boldsymbol{i}$
;
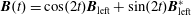 $\boldsymbol{B}(t)=\cos (2t)\boldsymbol{B}_{\text{left}}+\sin (2t)\boldsymbol{B}_{\text{left}}^{\ast }$
, where
 $\boldsymbol{i}$
is the vertical (right) vector field on
 $S^{3}$
: the Hopf field
 $\boldsymbol{i}=\boldsymbol{B}_{\text{right}}$
, constructed in § 2;
 $\boldsymbol{B}_{\text{left}}$
,
 $\boldsymbol{B}_{\text{left}}^{\ast }$
are two horizontal (left) vector fields: the geodesic vector field
 $\boldsymbol{B}_{\text{left}}$
, constructed in § 2.3 and its conjugated geodesic vector field
 $\boldsymbol{B}_{\text{left}}^{\ast }$
. By construction
 $\boldsymbol{B}_{\text{left}}$
and
 $\boldsymbol{B}_{\text{left}}^{\ast }$
are in the plane of the basic quaternion (right) vector fields
 $\boldsymbol{j}$
,
 $\boldsymbol{k}$
on
 $S^{3}$
.
Then, by formula (2.3), (2.10), equation (4.2) is satisfied:
 $\mathbf{rot}(\boldsymbol{v})=2\boldsymbol{v}$
,
 $\mathbf{rot}(\boldsymbol{B})=-2\boldsymbol{B}$
,
 $(\boldsymbol{v},\unicode[STIX]{x1D735})\boldsymbol{v}=0$
,
 $\mathbf{rot}(\boldsymbol{B})\times \boldsymbol{B}=0$
. Also (4.1) is satisfied:
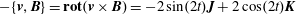 $-\{\boldsymbol{v},\boldsymbol{B}\}=\mathbf{rot}(\boldsymbol{v}\times \boldsymbol{B})=-2\sin (2t)\boldsymbol{J}+2\cos (2t)\boldsymbol{K}$
.
Example 2. Assume that the standard
 $S^{3}$
is non-homogeneous:
 $\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})=\boldsymbol{k}^{-2}(\,\boldsymbol{y})$
, as in Theorem 1,
 $k\in 3,4,\ldots ,$
is fixed. Define
 $\boldsymbol{v}=\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})\boldsymbol{I}$
,
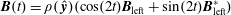 $\boldsymbol{B}(t)=\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})(\cos (2t)\boldsymbol{B}_{\text{left}}+\sin (2t)\boldsymbol{B}_{\text{left}}^{\ast })$
, where
 $\boldsymbol{i}$
is the Hopf vertical vector field on
 $S^{3}$
,
 $\boldsymbol{B}_{\text{left}}$
is the horizontal vector field, determined by the geodesic flow in Theorem 1, and
 $\boldsymbol{B}_{\text{left}}^{\ast }$
is vector horizontal field, determined by the conjugated geodesic flow. Then the (4.2) is satisfied:
 $\mathbf{rot}(\boldsymbol{v})=2\boldsymbol{v}$
; by Lemma 4, equation (2.16) we get:
 $\mathbf{rot}(\boldsymbol{B})=-2\boldsymbol{B}$
,
 $\mathbf{rot}(\boldsymbol{B})\times \boldsymbol{B}=0$
; the (4.1) is satisfied:
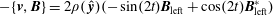 $-\{\boldsymbol{v},\boldsymbol{B}\}=2\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})(-\sin (2t)\boldsymbol{B}_{\text{left}}+\cos (2t)\boldsymbol{B}_{\text{left}}^{\ast })$
.
Example 2 admits the following properties: structural stability and hyperbolicity of magnetic flow. In Example 1 the Larmor radii of trajectories of particles are curved along the direction of the velocity. In Example 2 they are curved in the opposite direction.
5 Helicity invariants
Theorem 1 demonstrates that Ghys–Dehornoy hyperbolic flow (Dehornoy Reference Dehornoy2015) determines stationary solutions of the MHD-equations, which was recalled in § 4. As the main example we take the simplest flow with the Lorenz attractor. We will calculate quadratic helicities for this solution. The calculation is based on the standard arguments from ergodic theorems. The calculation of quadratic helicities
 $\unicode[STIX]{x1D712}^{(2)}$
is analytic. The calculation of
 $\unicode[STIX]{x1D712}^{[2]}$
is geometrical and possible with the assumption that the magnetic field configuration admits an additional symmetry. The calculation of
 $\unicode[STIX]{x1D712}^{[2]}$
for the magnetic configuration itself is an open problem.
For a homogeneous domain
 $\unicode[STIX]{x1D6FA}$
inequalities for magnetic field
 $\boldsymbol{B}$
:
 $$\begin{eqnarray}2\unicode[STIX]{x1D712}^{[2]}\geqslant \unicode[STIX]{x1D712}^{(2)}\text{vol}^{-1}(\unicode[STIX]{x1D6FA})\geqslant \unicode[STIX]{x1D712}^{2}\text{vol}^{-2}(\unicode[STIX]{x1D6FA})\end{eqnarray}$$
are satisfied (Akhmet’ev Reference Akhmet’ev2012). In these inequalities
 $\unicode[STIX]{x1D712}^{[2]}$
and
 $\unicode[STIX]{x1D712}^{(2)}$
are quadratic helicities and
 $\unicode[STIX]{x1D712}$
is the standard helicity. See Akhmet’ev (Reference Akhmet’ev2012) for definitions of the quadratic helicities. All of these are invariants in ideal MHD. For non-homogeneous domain
 $\unicode[STIX]{x1D6FA}$
with the density function
 $\unicode[STIX]{x1D70C}$
the inequalities are analogous (see Akhmet’ev et al. (Reference Akhmet’ev, Candelaresi and Smirnov2017) for the right inequality for
 $\unicode[STIX]{x1D712}^{(2)}$
in a non-homogeneous domain).
For the Hopf magnetic force-free field
 $\boldsymbol{B}_{\text{right}}=\boldsymbol{I}$
on the homogeneous
 $\unicode[STIX]{x1D6FA}=S^{3}$
we get:
 $$\begin{eqnarray}2\unicode[STIX]{x1D712}^{[2]}\equiv \unicode[STIX]{x1D712}^{(2)}\text{vol}^{-1}(S^{3})\equiv \unicode[STIX]{x1D712}^{2}\text{vol}^{-2}(S^{3}),\end{eqnarray}$$
where
 $\text{vol}(S^{3})$
is the volume of the sphere
 $S^{3}$
.
Theorem 2. The quadratic helicity
 $\unicode[STIX]{x1D712}^{(2)}$
of the magnetic field
 $\boldsymbol{B}_{\text{left}}$
in the non-homogeneous domain
 $\unicode[STIX]{x1D6FA}$
, constructed by Theorem 1, takes the minimal possible value
 $$\begin{eqnarray}\unicode[STIX]{x1D712}^{(2)}\equiv \frac{\unicode[STIX]{x1D712}^{2}}{\text{vol}(\unicode[STIX]{x1D6FA})},\end{eqnarray}$$
where
 $\unicode[STIX]{x1D712}$
is the helicity of
 $\boldsymbol{B}_{\text{left}}$
.
Proof. Let us prove that the field line helicity function
 ${\mathcal{A}}(\boldsymbol{x})$
(Yeates & Hornig Reference Yeates and Hornig2011) is constant in
 $\unicode[STIX]{x1D6FA}=S^{3}\setminus l$
. This function is defined by the average of
 $(\boldsymbol{A},\boldsymbol{B})\unicode[STIX]{x1D70C}$
along the magnetic line, issued from the point
 $\boldsymbol{x}\in \unicode[STIX]{x1D6FA}$
. By (2.16) the vector potential
 $\boldsymbol{A}$
coincides with
 $1/2\boldsymbol{B}$
and
 $(\boldsymbol{B},\boldsymbol{B})=k^{2}(\,\hat{\boldsymbol{y}})$
,
 $\unicode[STIX]{x1D70C}(\,\hat{\boldsymbol{y}})=k^{-2}(\,\hat{\boldsymbol{y}})$
by Theorem 1(iii). We get that the function
 ${\mathcal{A}}(\boldsymbol{x})$
is a constant, this implies that asymptotic linking number is uniformly distributed in
 $\unicode[STIX]{x1D6FA}$
and
 $\unicode[STIX]{x1D712}^{(2)}$
contains the minimal value.
The magnetic field
 $\boldsymbol{B}_{\text{left}}$
on
 $S^{3}$
from Theorem 1 admits a cyclic
 $Z_{4}$
-transformation
 $\boldsymbol{i}:S^{3}\rightarrow S^{3}$
along the Hopf fibres, which is defined by the complex multiplication. This transformation maps
 $\boldsymbol{J}$
to
 $-\boldsymbol{J}$
in Example 1, and maps
 $\boldsymbol{B}_{\text{left}}$
to
 $-\boldsymbol{B}_{\text{left}}$
in Example 2. On the non-homogeneous domain which is the quotient
 $\hat{\unicode[STIX]{x1D6FA}}=S^{3}/\boldsymbol{J}$
with the total volume
 $\text{vol}(\hat{\unicode[STIX]{x1D6FA}})$
a magnetic field
 $\hat{\boldsymbol{B}}_{\text{left}}$
with the prescribed local coefficient system is well defined and the quadratic helicities
 $\hat{\unicode[STIX]{x1D712}}^{[2]}$
and
 $\hat{\unicode[STIX]{x1D712}}^{(2)}$
are well defined. This construction is considered by Zelikin (Reference Zelikin2008) as a model of superconductivity.
Theorem 3. The quadratic helicities
 $\hat{\unicode[STIX]{x1D712}}^{[2]}$
and
 $\hat{\unicode[STIX]{x1D712}}^{(2)}$
, and the helicity
 $\unicode[STIX]{x1D712}$
of
 $\hat{\boldsymbol{B}}_{\text{left}}$
in
 $\hat{\unicode[STIX]{x1D6FA}}$
satisfy the equation:
 $$\begin{eqnarray}\hat{\unicode[STIX]{x1D712}}^{[2]}\equiv 2\hat{\unicode[STIX]{x1D712}}^{(2)}\text{vol}^{-1}(\hat{\unicode[STIX]{x1D6FA}})\equiv \hat{\unicode[STIX]{x1D712}}^{2}\text{vol}^{-2}(\hat{\unicode[STIX]{x1D6FA}}).\end{eqnarray}$$
Proof. Let us calculate quadratic helicities for magnetic field in
 $S^{3}/\boldsymbol{i}=\unicode[STIX]{x1D6EC}(S^{2})/I$
, equipped with the metric on the Lobachevskii plane
 $L$
.
Take the universal branching covering
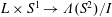 $L\times S^{1}\rightarrow \unicode[STIX]{x1D6EC}(S^{2})/I$
which is the quotient of the covering space
 $L\times S^{1}$
by the corresponding Fuchsian group
 $G$
. A magnetic line
 $l$
in
 $\unicode[STIX]{x1D6EC}(S^{2})/I$
is represented by the corresponding collection
 $\{\unicode[STIX]{x1D706}_{i}\}$
of non-orientable geodesics on the Poincaré plane, invariant with respect to
 $G$
. For rational geodesic the collection
 $\{\unicode[STIX]{x1D706}_{i}\}$
is finite in the fundamental domain
 $P\subset L$
of
 $G$
. For generic
 $l$
the collection
 $\{\unicode[STIX]{x1D706}_{i}\}$
is dense in
 $L$
. Because the involution
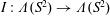 $I:\unicode[STIX]{x1D6EC}(S^{2})\rightarrow \unicode[STIX]{x1D6EC}(S^{2})$
, geodesics
 $\unicode[STIX]{x1D706}_{i}$
and
 $-\unicode[STIX]{x1D706}_{i}$
with the opposite orientation are correspondingly identified.
The linking number
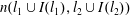 $n(l_{1}\cup I(l_{1}),l_{2}\cup I(l_{2}))$
between two closed magnetic lines
 $l_{1}$
,
 $l_{2}$
is calculated as the number of intersection points in the fundamental domain
 $P$
of the two collections
 $\{\unicode[STIX]{x1D706}_{1,j}\}$
,
 $\{\unicode[STIX]{x1D706}_{2,i}\}$
of rational geodesics. Each intersection point is taken with the negative sign. This statement is a particular case of Birkhoff’s theorem about the linking number of two acyclic geodesics. The collection
 $\{\unicode[STIX]{x1D706}_{i}\cup -\unicode[STIX]{x1D706}_{i}\}$
is acyclic (is null-homologous). A calculation of the linking number
 $n(l_{1},l_{2})$
is complicated (Dehornoy Reference Dehornoy2015).
Denote
 $l_{a}\cup I(l_{a})$
,
 $a=1,2$
by
 $\bar{l}_{a}$
. After the normalization of the linking number with respect to magnetic lengths of
 $\bar{l}_{1},\bar{l}_{2}$
, we get much simpler calculation of
 $n(\bar{l}_{1},\bar{l}_{2})$
. The number of intersection points in
 $P$
of two geodesic is calculated as
 $\unicode[STIX]{x1D70F}^{2}S^{-1}(P)$
, where
 $\unicode[STIX]{x1D70F}$
is the natural parameter on geodesic,
 $S(P)$
is the square of the domain
 $P$
(the complete proof is based on ergodicity and is omitted). We get
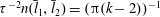 $\unicode[STIX]{x1D70F}^{-2}n(\bar{l}_{1},\bar{l}_{2})=(\unicode[STIX]{x03C0}(k-2))^{-1}$
, where
 $\unicode[STIX]{x1D70F}$
is the parameter of the magnetic lengths,
 $\unicode[STIX]{x03C0}(k-2)$
is the square of the fundamental domain (
 $k$
-angles)
 $P(k)$
on the Lobachevskii plane.
For the square of the helicity we get:
 $$\begin{eqnarray}\hat{\unicode[STIX]{x1D712}}^{2}=(\unicode[STIX]{x03C0}(k-2))^{-2}\text{vol}^{4}(\unicode[STIX]{x1D6EC}(S^{2})/I).\end{eqnarray}$$
For the quadratic helicity
 $\hat{\unicode[STIX]{x1D712}}^{(2)}$
is better to use the formula for triples magnetic lines, (see Akhmet’ev et al. (Reference Akhmet’ev, Candelaresi and Smirnov2017) and Akhmet’ev (Reference Akhmet’ev2012)). We get:
 $$\begin{eqnarray}\hat{\unicode[STIX]{x1D712}}^{(2)}=(\unicode[STIX]{x03C0}(k-2))^{-2}\text{vol}^{3}(\unicode[STIX]{x1D6EC}(S^{2})/I).\end{eqnarray}$$
For the quadratic helicity
 $\hat{\unicode[STIX]{x1D712}}^{[2]}$
we get:
 $$\begin{eqnarray}2\hat{\unicode[STIX]{x1D712}}^{[2]}=(\unicode[STIX]{x03C0}(k-2))^{-2}\text{vol}^{2}(\unicode[STIX]{x1D6EC}(S^{2})/I).\end{eqnarray}$$
Acknowledgements
P.M.A. was supported in part by the RFBR GFEN 17-52-53203; RFBR 16-51-150005. S.C. acknowledges financial support from the UK’s STFC (grant number ST/K000993). A.Y.S. acknowledges financial support from the Ministry of Education and Science of the Russian Federation in the framework of increase Competitiveness Program of NUST ‘MISIS’.