1. Introduction
During offshore operations, ships are subjected to wave disturbances from various directions, making it challenging to maintain a stable working environment. Consequently, shipborne stabilisation platforms have been widely developed to provide relatively stable working conditions at sea, minimising the impact of wave-induced motion on operations [Reference Tian, Zhang, Lv, Wang and Liu1–Reference Liu, Du, Li and Li3]. Traditional shipborne stabilisation platforms typically employ serial turntables, which rely on gyroscopes for control and attitude adjustments. These turntables are commonly limited to single-axis, dual-axis, or three-axis configurations, which restrict their capability to compensate for the full six degrees of freedom (6-DOF) motion experienced by ships. In contrast, 6-DOF parallel mechanisms can theoretically achieve comprehensive compensation for disturbances and provide high load capacity due to their unique structural design. Therefore, parallel mechanisms offer advantages for shipborne stabilisation applications involving heavy loads. Thus, parallel shipborne stabilisation platforms have attracted increasing attention.
In a parallel shipborne stabilisation platform, the lower platform is rigidly connected to the ship, and the upper platform maintains nearly constant pose through the motion of the limbs. Due to the unpredictability of wave fluctuations and the approximations in system modelling, real-time control that does not rely on precise mathematical models is crucial for isolating disturbances from the lower platform. Accelerometers are mounted on the lower platform to measure its movement acceleration, and the position of the lower platform cannot be accurately measured. In general, the position of the lower platform is indirectly obtained by double integrating the accelerometer output, which can result in significant errors. Consequently, the control strategy for the shipborne stabilisation platform must exhibit high accuracy and robustness.
Some control strategies have been proposed for stabilisation platforms, such as the extended sliding mode disturbance observer [Reference Chang, Yang, Cao and Li4], backstepping adaptive control [Reference Guo, Tan, Yang and Zhang5], and sliding mode variable structure control [Reference Guo and Tan6]. For parallel shipborne stabilisation platforms, the control strategies can be mainly categorised into two types. The first type relies on accurate mathematical modelling of the stabilisation platforms and prediction of ship movements. This includes active-passive vibration control [Reference Bi, Ma, Wang, Yang and Lv7], model predictive control [Reference Liu, Yuan, Xiao and Xiao8–Reference Qiang, Jin, Feng, Xue and Zhang10], smooth integral sliding mode control [Reference Ramesh, Chanlanga and Bandyopadhyay11], nonsingular fast terminal sliding mode control [Reference Wang and Liu12], and small attitude manoeuvre vibration isolation control [Reference Chi, Ma, Wang and Zhao13]. Although the first type of methods can achieve good control effects, they are not widely used due to the difficulty of obtaining accurate mathematical models of the stabilisation platforms. The second type does not rely on accurate mathematical models, such as the adaptive smooth integral sliding mode algorithm [Reference Safeena, Ramesh and Jiji14], the PID controller and compensator [Reference Amit and Hamad15–Reference Ghanifar, Kamzan and Tayefi18] and the neuro-fuzzy adaptive control [Reference Mojtaba, Mahdi and Hossein19, Reference Khanbabayi and Noorani20]. Due to the inherent characteristics of parallel mechanisms such as strongly coupled nonlinear dynamics and multi-closed-loop chain topology [Reference Fijany and Fried21–Reference Wang, Qiu, He, Wu, Xu and Zhao27], some algorithms struggle to achieve real-time disturbance compensation. Moreover, many advanced intelligent control methods, particularly neural network-based controllers, require extensive offline training data and significant computational resources for real-time adaptation, which can hinder performance under rapidly changing wave conditions [Reference Li, Li, Bai and Du28, Reference Luo, Hu and Li29]. Additionally, learning-based optimisation techniques, such as genetic algorithm-tuned PID controllers, are typically optimised offline, resulting in fixed parameters that lack the necessary adaptability to handle uncertainties in maritime environments [Reference Wang and Wang30, Reference Dilimulati and Bruha31].
In summary, existing research on the motion control of parallel shipborne stabilisation platforms still faces significant deficiencies, including reliance on precise modelling, inadequate real-time compensation capabilities, high demands for data and computational power, and a lack of adaptability. To address these deficiencies, this paper proposes a novel integrated control strategy that combines fuzzy gain control (FGC) with dynamic feedforward control (DFFC). By combining the precise internal disturbance rejection of DFFC with the model-free, adaptive robustness of FGC to external disturbances, this approach aims to provide substantially broader adaptability (platform-agnostic capability) and greater robustness, while also enhancing real-time compensation performance. The novelty of this work can be summarised in two key points. Firstly, with an emphasis on the operational requirements of shipborne stabilisation platforms, DFFC is designed to compensate for the platform’s dynamic characteristics, while FGC addresses the complex external wave disturbances. Secondly, the scaling modules are introduced to FGC to enhance the convenience of applying FGC in various application environments.
The structure of this paper is organised as follows. Section 2 derives the kinematic and dynamic model of the platform and studies the ship’s disturbed motion. Section 3 presents the design of the control strategy, while Section 4 covers the overall simulation and experimental verification. Section 5 summarises the content of the paper.
2. Stabilisation platform kinematics and ship disturbed motion
2.1. Kinematics and dynamics
As shown in Figure 1, the stabilisation platform consists of an upper platform, a lower platform connected to the ship, and six identical UPS limbs (Universal-Prismatic-Spherical joints) arranged in a standard 6-UPS configuration. The lower platform coordinate system
 $e-x_{e}y_{e}z_{e}$
and the upper platform coordinate system
 $p-x_{p}y_{p}z_{p}$
are attached to their mass centres, respectively. The coordinate system
 $e-x_{e}y_{e}z_{e}$
is the reference coordinate system, and the pose of the upper platform relative to the reference coordinate system is described by the vector
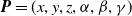 $\boldsymbol{P}=(x,y,z,\alpha ,\beta ,\gamma )$
, where
 $(x,y,z)$
represents the positional displacement and
 $(\alpha ,\beta ,\gamma )$
are the Cardan angles representing rotations about the
 $x_{e}$
,
 $y_{e}$
, and
 $z_{e}$
axes, respectively.
3D model and schematic diagram of 6-UPS Stewart platform.

Let
 $A_{i}$
be the centre of the U joint connecting limb
 $i$
with the lower platform, and let
 $B_{i}$
be the centre of the S joint connecting the limb with the upper platform.
 $\boldsymbol{D}$
represents the vector from the centre of the lower platform to the centre of the upper platform in its initial position, and
 $\boldsymbol{V}$
denotes the displacement of the centre of the upper platform relative to its initial position. Similarly,
 $\boldsymbol{a}_{i}$
and
 $\boldsymbol{l}_{i}$
are the position vectors from
 $\textrm{e}$
to
 $\textrm{A}_{i}$
and from
 $\textrm{A}_{i}$
to
 $\textrm{B}_{i}$
, respectively. The four vectors mentioned above are represented in
 $e-x_{e}y_{e}z_{e}$
, whereas
 $\boldsymbol{b}_{i}$
, denoting the vector from
 $p$
to
 $\textrm{B}_{i}$
, is represented in
 $p-x_{p}y_{p}z_{p}$
. Let
 ${}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}$
be the orientation matrix of
 $p-x_{p}y_{p}z_{p}$
with respect to
 $e-x_{e}y_{e}z_{e}$
. Using the vector geometry in Figure 1, the vector loop equation can be expressed as
 \begin{equation}\boldsymbol{D}+\boldsymbol{V}+{}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{i}-\boldsymbol{l}_{i}-\boldsymbol{a}_{i}=\mathbf{0},\, i=1,2,\ldots ,6\end{equation}
The length vector of limb
 $i$
can be expressed as
 \begin{equation}\boldsymbol{l}_{i}=\boldsymbol{D}+\boldsymbol{V}+{}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{i}-\boldsymbol{a}_{i}\end{equation}
The scalar length
 $l_{i}$
of each limb can be written as
 \begin{equation}l_{i}=\sqrt{\left(\boldsymbol{D}+\boldsymbol{V}+{}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{i}-\boldsymbol{a}_{i}\right)^{\textrm{T}}\left(\boldsymbol{D}+\boldsymbol{V}+{}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{i}-\boldsymbol{a}_{i}\right)}\end{equation}
This matrix
 ${}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}$
can be expressed in terms of three Cardan angles, that is,
 ${\unicode[Arial]{x03B1}}$
about the
 $x$
axis,
 ${\unicode[Arial]{x03B2}}$
about the
 $y$
axis and
 ${\unicode[Arial]{x03B3}}$
about the
 $z$
axis, as
 \begin{equation}{}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}=\boldsymbol{Rot}(x,\alpha)\boldsymbol{Rot}(y,\beta)\boldsymbol{Rot}(z,\gamma)\end{equation}
Given a pose
 $\boldsymbol{P}$
, Eq. (4) provides
 ${}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}$
, allowing for the direct computation of all limb lengths
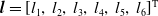 $\boldsymbol{l}=[l_{1},\, l_{2},\, l_{3},\, l_{4},\, l_{5},\, l_{6}]^{\textrm{T}}$
via Eq. (3). Therefore, the inverse displacement problem can be solved by
 \begin{equation}\boldsymbol{l}=f(\boldsymbol{P})=f\left(\left[x\, y\, z\, \alpha \, \beta \, \gamma \right]^{T}\right)\end{equation}
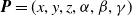 $\boldsymbol{P}=(x,y,z,\alpha ,\beta ,\gamma )$
can be decomposed into the position vector
 $\boldsymbol{L}=[x\, y\, z]^{\textrm{T}}$
and the orientation vector
 $\boldsymbol{G}=[\alpha \, \beta \, \gamma ]^{\textrm{T}}$
. To relate the platform’s motion to limb actuation rates, we analyse the velocity kinematics. The velocity of point
 $\textrm{B}_{i}$
can be expressed in two ways. As a point rigidly attached to the moving platform, the velocity of
 $\textrm{B}_{i}$
can be expressed as a function of the upper platform’s velocity and angular velocity.
 \begin{equation}\boldsymbol{v}_{Bi}=\boldsymbol{\omega }_{p}\times \left({}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{i}\right)+\boldsymbol{v}_{\textrm{p}}\end{equation}
where
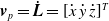 $\boldsymbol{v}_{p}=\dot{\boldsymbol{L}}=[\dot{x}\, \dot{y}\, \dot{z}]^{T}$
is the linear velocity and
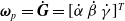 $\boldsymbol{\omega }_{p}=\dot{\boldsymbol{G}}=[\dot{\alpha }\, \dot{\beta }\, \dot{\gamma }]^{T}$
is the angular velocity for the upper platform. As a point constrained by limb
 $i$
,
 $\boldsymbol{v}_{\textrm{B}i}$
can also be expressed as
 \begin{equation}\boldsymbol{v}_{\textrm{B}i}=\boldsymbol{\omega }_{li}\times \boldsymbol{l}_{i}+\dot{\boldsymbol{l}_{i}}\boldsymbol{n}_{i}\end{equation}
where
 $\boldsymbol{\omega }_{li}$
represents the angular velocity of limb
 $i$
,
 $\dot{\boldsymbol{l}_{i}}$
represents the length variation rate of limb
 $i$
, and
 $\boldsymbol{n}_{i}$
indicates the unit vector in the axial direction of the limb. The component of
 $\boldsymbol{v}_{\textrm{B}i}$
along the limb axis
 $\boldsymbol{n}_{i}$
must be equal in both descriptions. Taking the dot product of both Eq. (6) and Eq. (7) with
 $\boldsymbol{n}_{i}$
and equating the results yields
 \begin{equation}\boldsymbol{\omega }_{\textrm{p}}\times \left({}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{i}\right)\cdot \boldsymbol{n}_{i}+\boldsymbol{v}_{p}\cdot \boldsymbol{n}_{i}=\boldsymbol{\omega }_{li}\times \boldsymbol{l}_{i}\cdot \boldsymbol{n}_{i}+\dot{\boldsymbol{l}_{i}}\boldsymbol{n}_{i}\cdot \boldsymbol{n}_{i}\end{equation}
Note that
 $\boldsymbol{n}_{i}\cdot \boldsymbol{n}_{i}=1$
and
 $\boldsymbol{\omega }_{li}\times \boldsymbol{l}_{i}\cdot \boldsymbol{n}_{i}=0$
since
 $\boldsymbol{l}_{i}$
is parallel to
 $\boldsymbol{n}_{i}$
, simplifying Eq. (8) and using the scalar triple product identity
 $(A\times B)\cdot C=A\cdot (B\times C)$
, we can obtain
 \begin{equation}\dot{\boldsymbol{l}_{i}}=\boldsymbol{v}_{\textrm{p}}\cdot \boldsymbol{n}_{i}+\left(\left({}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{i}\right)\times \boldsymbol{n}_{i}\right)\boldsymbol{\omega }_{\textrm{p}}=\left[\begin{array}{cc} \boldsymbol{n}_{i} & \left({}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{i}\right)\times \boldsymbol{n}_{i} \end{array}\right]\left[\begin{array}{c} \boldsymbol{v}_{p}\\ \boldsymbol{\omega }_{p} \end{array}\right]\end{equation}
Stacking Eq. (9) for all 6 limbs gives the velocity Jacobian relationship
 \begin{equation}\dot{\boldsymbol{l}}=\boldsymbol{J}_{v}\cdot \dot{\boldsymbol{P}}\end{equation}
where
 \begin{equation*} \begin{array}{c} \dot{\boldsymbol{l}}=\left[\dot{\boldsymbol{l}_{1}}\, \dot{\boldsymbol{l}_{2}}\, \dot{\boldsymbol{l}_{3}}\, \dot{\boldsymbol{l}_{4}}\, \dot{\boldsymbol{l}_{5}}\, \dot{\boldsymbol{l}_{6}}\right]^{T} \end{array} \end{equation*}
 \begin{equation*} \begin{array}{c} \boldsymbol{J}_{v}=\left[\begin{array}{c@{\quad}c} \boldsymbol{n}_{1} & \left({}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{1}\right)\times \boldsymbol{n}_{1}\\ \vdots & \vdots \\[2pt] \boldsymbol{n}_{6} & \left({}_{\mathrm{p}}^{\mathrm{e}}{\boldsymbol{R}}\cdot \boldsymbol{b}_{6}\right)\times \boldsymbol{n}_{6} \end{array}\right] \end{array} \end{equation*}
 \begin{equation*} \begin{array}{c} \dot{\boldsymbol{P}}=\left[\begin{array}{c} \boldsymbol{v}_{p}\\ \boldsymbol{\omega }_{p} \end{array}\right] \end{array} \end{equation*}
Each row
 $i$
of
 $\boldsymbol{J}_{v}$
maps the platform twist
 $\dot{\boldsymbol{P}}$
to the extension rate
 $\dot{\boldsymbol{l}_{i}}$
of limb
 $i$
.
Using the kinematic relationships and Jacobian derived above, the inverse dynamics of the shipborne stabilisation platform, that is, calculating the required limb forces
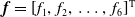 $\boldsymbol{f}=[f_{1},\, f_{2},\, \ldots ,\, f_{6}]^{\textrm{T}}$
to achieve a desired platform motion (
 $\boldsymbol{P}$
,
 $\dot{\boldsymbol{P}}$
,
 $\ddot{\boldsymbol{P}}$
), can be formulated as
 \begin{equation}\boldsymbol{f}=\boldsymbol{J}^{-1}(\boldsymbol{D}(\boldsymbol{P})\ddot{\boldsymbol{P}}+\boldsymbol{H}(\boldsymbol{P},\dot{\boldsymbol{P}})\dot{\boldsymbol{P}}+\boldsymbol{G}(\boldsymbol{P}))\end{equation}
where
 $\boldsymbol{f}$
is the vector consisting of the six limb driving forces,
 $\boldsymbol{J}$
is the Jacobian matrix,
 $\boldsymbol{D}(\boldsymbol{P})$
is the overall inertia matrix of the platform,
 $\boldsymbol{H}(\boldsymbol{P},\dot{\boldsymbol{P}})$
is the overall matrix of centrifugal and Coriolis forces, and
 $\boldsymbol{G}(\boldsymbol{P})$
is the gravitational vector acting on the platform.
2.2. Ocean wave fluctuation and ship disturbed motion
The random fluctuation of ocean waves causes disturbed motions of ships. Essentially, the disturbed motion of the ship serves as the input to the control system of the stabilisation platform. Thus, the disturbed motion of the ship is required to study the control of the stabilisation platform.
A widely accepted stochastic wave model is used, and the wave height can be expressed as
 \begin{equation}\zeta (x,y,t)=\sum _{i=1}^{\infty }\sum _{j=1}^{\infty }a_{ij}\cos \left[k_{i}\left(x\cos \theta _{j}+y\sin \theta _{j}\right)-\omega _{i}t+\varepsilon _{ij}\right]\end{equation}
where
 $\zeta (x,y,t)$
represents the wave height at point
 $(x,y)$
on the horizontal projection plane at time
 $t$
,
 $a_{ij}$
is the amplitude of the wave,
 $k_{i}$
is the wave number,
 $\theta _{j}$
is the wave direction,
 $\omega _{i}$
is the angular frequency of the wave, and
 $\varepsilon _{ij}$
is the initial phase of the wave, which is a random value in the interval
 $[0,\, 2{\unicode[Arial]{x03C0}} ]$
.
Generally, sea states are classified into levels 0–9 according to established maritime standards. Level 5 is characterised as moderate waves with significant wave heights typically ranging from 2.5 to 4 m, along with an increasingly frequent occurrence of prominent wave crests. It is selected as the representative sea state condition for this study. The selection avoids the extreme complexities and potential saturation limits associated with very high sea states (Levels 6–9). These higher levels often involve survivability rather than operational performance, and may require specialised platform design considerations that exceed the scope of this control algorithm study. Taking a Level 5 sea state as an example, frequency increment
 $\Delta \omega$
can be selected as
 $0.08\text{ rad}/\textrm{s}$
. A power spectrum is selected for a Level 5 sea state [Reference Tang, Zhao, Zhang and Peng32]. The wave power spectrum is obtained in the frequency range of [0.2, 2.4] (rad/s).
 \begin{equation}S(\omega _{i})=\frac{124\times 3.75^{2}}{8^{4}\cdot \omega ^{2}}\exp \left(-\frac{497}{8^{4}\cdot \omega ^{4}}\right)\end{equation}
Substituting the relationship between amplitude and energy into the wave motion model at a given point, and utilising the equation
 $\alpha _{i}=a_{i}\omega _{i}^{2}/g$
in the model of the slope of the wave surface, the wave motion model can be rewritten as
 \begin{equation}\begin{cases} \zeta (t)=\displaystyle\sum\limits _{i=1}^{\infty }\sqrt{2S(\omega _{i})\Delta \omega }\cos \left(\omega _{i}t+\varepsilon _{i}\right)\\[11pt] \alpha (t)=\displaystyle\sum\limits _{i=1}^{\infty }\dfrac{\omega _{i}^{2}}{g}\sqrt{2S(\omega _{i})\Delta \omega }\cos \left(\omega _{i}t+\varepsilon _{i}\right) \end{cases}\end{equation}
where
 $\zeta (t)$
represents the wave amplitude, and
 $\alpha (t)$
represents the slope of the wave surface.
Based on the wave fluctuation model and the power spectrum of a Level 5 sea state, the wave disturbance forces and moments can be expressed as
 \begin{equation}\begin{cases} F_{2}(iT_{0})=\displaystyle\sum\limits _{k=1}^{30}\sqrt{2\cdot S(\omega _{i})\Delta \omega }\sqrt{F_{2\textrm{Rk}}^{2}+F_{2\textrm{Ik}}^{2}}\sin \left(\omega (k)\cdot i\cdot T_{0}+\arctan \dfrac{F_{2\textrm{Ik}}}{F_{2\textrm{Rk}}}\right)\\[12pt] F_{4}(iT_{0})=\displaystyle\sum\limits _{k=1}^{30}\sqrt{2\cdot S(\omega _{i})\Delta \omega }\sqrt{F_{4\textrm{Rk}}^{2}+F_{4\textrm{Ik}}^{2}}\sin \left(\omega (k)\cdot i\cdot T_{0}+\arctan \dfrac{F_{4\textrm{Ik}}}{F_{4\textrm{Rk}}}\right)\\[12pt] F_{6}(iT_{0})=\displaystyle\sum\limits _{k=1}^{30}\sqrt{2\cdot S(\omega _{i})\Delta \omega }\sqrt{F_{6\textrm{Rk}}^{2}+F_{6\textrm{Ik}}^{2}}\sin \left(\omega (k)\cdot i\cdot T_{0}+\arctan \dfrac{F_{6\textrm{Ik}}}{F_{6\textrm{Rk}}}\right) \end{cases}\end{equation}
where
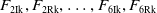 $F_{2\textrm{Ik}},F_{2\textrm{Rk}},\ldots ,F_{6\textrm{Ik}},F_{6\textrm{Rk}}$
represent the measured data of wave disturbance forces and moments corresponding to different frequencies, referencing the existing measured data from the studies [Reference Tang, Zhao, Zhang and Peng32].
After obtaining the lateral disturbance forces and moments acting on the ship, the coupled motion equations for lateral movement can be used to solve for lateral sway, roll, and yaw motion. The lateral dynamic equations of the ship can be expressed as
 \begin{equation}\begin{cases} \left(m+a_{22}\right)\ddot{y}+b_{22}\dot{y}+c_{22}y+a_{24}\ddot{\phi }+b_{24}\dot{\phi }+a_{26}\ddot{\psi }+b_{26}\dot{\psi }=nL_{\textrm{R}}+F_{2}\\[4pt] a_{42}\ddot{y}+b_{42}\dot{y}+\left(I_{4}+a_{44}\right)\ddot{\phi }+b_{44}\dot{\phi }+c_{44}\phi +a_{46}\ddot{\psi }+b_{46}\dot{\psi }=nL_{\textrm{R}}Z_{\textrm{R}}+F_{4}\\[4pt] a_{62}\ddot{y}+b_{62}\dot{y}+a_{64}\ddot{\phi }+b_{64}\dot{\phi }+\left(I_{6}+a_{66}\right)\ddot{\psi }+b_{66}\dot{\psi }+c_{66}\psi =nL_{\textrm{R}}X_{\textrm{R}}+F_{6} \end{cases}\end{equation}
where
 $n$
represents the number of rudders, which can be taken as
 $n=2$
. The lift force for the rudders is given by
 $L_{\textrm{R}}=\frac{1}{2}\rho \textrm{A}_{\textrm{R}}\textrm{V}^{2}\textrm{C}_{{\unicode[Arial]{x03B3}} }$
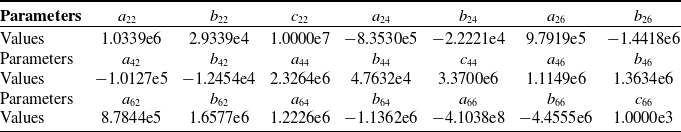
. The parameters in Eq. (16) are detailed in Table I.
Parameters in lateral dynamic equations of ship.

In Eq. (16), the variables are coupled with each other and a Simulink model is employed to solve them. The ship’s lateral sway, roll, and yaw motion derived from the solution are shown in Figure 2. The lower platform of the shipborne stabilisation platform is rigidly connected to the ship. Thus, the resulting ship motion curves can be used as input for simulating the motion of the lower platform. It can be observed that the ship’s disturbed motion shows significant fluctuations with weak regularity, which makes it challenging to predict.
Lateral sway, roll, and yaw motion of ship.

3. Integrated control strategy
The shipborne stabilisation platform provides a stable operating environment for onboard equipment, which is attached to the upper platform of the stabilisation platform. However, the internal disturbances from platform dynamic characteristics and external disturbances from waves can significantly affect the platform stability. Thus, a robust control strategy is required. In this paper, an integrated control strategy combining DFFC and FGC is proposed, as shown in Figure 3. This combination is selected for their complementary strengths and unique suitability for the distinct challenges:
Integrated control strategy.

DFFC is indispensable for its ability to compensate for the dominant disturbance moments originating from the platform’s own motors and inherent dynamic coupling. This targeted compensation significantly enhances robustness against these well-understood internal disturbances, a capability which is not readily achieved by standard feedback or purely adaptive schemes.
FGC is uniquely advantageous for handling the complex external wave disturbances. Unlike adaptive controllers requiring extensive training data or predictive methods reliant on accurate disturbance models (often unavailable for unpredictable waves), FGC operates based on intuitive fuzzy rules. These rules enable real-time, adaptive adjustment of controller gains, which inherently desensitises the system to input variations and uncertainties. This provides exceptional robustness and adaptability in the face of highly variable sea conditions without demanding complex offline identification or large datasets.
3.1. Dynamic feedforward control
The block diagram of the DFFC is shown in Figure 4.
 $X(s)$
represents the expected limb length variation for one limb,
 $G_{\textrm{f}}$
represents the transfer function of the feedforward controller,
 $\tau (s)$
indicates the disturbance moment, and
 $L(s)$
represents the change in limb length as the system output.
Control system model after adding DFFC.

The transfer function from the disturbance moment to the output change in limb length can be written as
 \begin{equation}\frac{L(s)}{\tau (s)}=\frac{G_{f}G_{1}G_{2}G_{3}G_{4}-G_{3}G_{4}}{G_{1}G_{2}G_{3}G_{4}+G_{2}G_{3}G_{5}+1}\end{equation}
where
 $G_{1}=\frac{K_{p}s+K_{p}K_{i}}{s}$
,
 $G_{2}=\frac{K_{t}}{Ls+R}$
,
 $G_{3}=\frac{1}{Js}$
,
 $G_{4}=\frac{1}{s}$
and
 $G_{5}=K_{{e}}+K_{\textrm{vfb}}$
. To ensure that the effect of the disturbance moment is completely counteracted, it is required that
 $\frac{L(\textrm{s})}{{\unicode[Arial]{x03C4}} (\textrm{s})}=0$
. Then, it can be obtained that the transfer function of the feedforward controller is
 $G_{\textrm{f}}=\frac{1}{G_{1}G_{2}}$
. In this case, the differential component
 $s$
is difficult to realise and can be generally approximated by
 $\frac{s}{N_{\textrm{c}}s+1}$
with
 $N_{\textrm{c}}=0.001$
. Thus, the transfer function of the feedforward controller can be rewritten as
 \begin{equation}G_{{f}}=\frac{Ls}{K_{{p}}K_{{t}}N_{{c}}s+K_{{p}}K_{{t}}}+\frac{\left(R-LK_{{i}}\right)s}{K_{{p}}K_{{t}}s+K_{{p}}K_{{i}}K_{{t}}}\end{equation}
The DFFC for one limb of the stabilisation platform is simulated, as shown in Figure 5. The input trajectory is a sine wave with a maximum value of 2 mm, a minimum value of 0 mm, and a period of 4 s. Through simulation comparison, the control effects of the standard control loop of the system (including PI control and linear feedforward of speed and acceleration, as shown in Figure 4) can be evaluated before and after the addition of DFFC. Situation 1 represents the standard control loop without disturbance torque, Situation 2 represents the standard control loop with disturbance torque, and Situation 3 represents DFFC plus standard control loop with disturbance torque. It can be seen that the tracking error of the system significantly increases for the majority of the time after the disturbance moment is introduced, and the magnitudes of the positive and negative peaks are no longer approximately equal, resulting in an overall shift of the curve. Through DFFC, the tracking error of the system can be nearly restored to a level comparable to that prior to the introduction of the disturbance moment, demonstrating the suppression effect of the introduced DFFC on the disturbance moment. From the local magnified view in Figure 5(b), it is evident that the curve corresponding to the feedforward correction does not completely coincide with that before adding the disturbance moment. The role of the DFFC is to input the feedforward signal to the system during each control cycle, thereby stabilising the control effect to maintain the state prior to the introduction of the disturbance moment.
Tracking errors under DFFC.

3.2. Design of integrated control strategy
To effectively utilise the feedback information from the tracking error, the fuzzy controller inputs are defined as the tracking error
 $e$
and its derivative
 $de$
. The FGC is designed to adaptively adjust the gains of the feedback controller within the PMAC control card. In this study, the standard feedback control loop provided by the PMAC card uses a PI structure with linear velocity and acceleration feedforward, as shown in Figure 4. Consequently, the FGC focuses on tuning the proportional gain (
 $K_{p}$
) and integral gain (
 $K_{i}$
) of the PI controller. The derivative gain (
 $K_{d}$
) is not adjusted by the fuzzy logic module since it is not employed in the standard PI feedback loop configuration of the PMAC. The output variables
 $\Delta K_{p}$
and
 $\Delta K_{i}$
indicate the adjustments in the proportional gain coefficient
 $K_{p}$
and the integral gain coefficient
 $K_{i}$
, respectively. Therefore, the fuzzy controller has two input variables and two output variables. The ranges of these input and output variables depend on actual operating conditions. When designing the fuzzy controller, the membership functions need to be modified to adjust the ranges of input and output variables, which may be cumbersome. Therefore, this paper specifies the variation ranges and encapsulates the fuzzy controller, and incorporates external scaling modules to adapt to varying operating conditions.
After the variation ranges for the input and output variables are determined, the membership functions need to be established. Taking the input tracking error
 $e$
as an example, its membership function is illustrated in Figure 6. This fuzzification process maps
 $e$
to seven fuzzy terms: Negative Big, Negative Medium, Negative Small, Zero, Positive Small, Positive Medium, and Positive Big. A fuzzy inference mechanism is constructed, with fuzzy rules for
 ${\unicode[Arial]{x0394}} K_{\textrm{p}}$
and
 ${\unicode[Arial]{x0394}} K_{\textrm{i}}$
presented in three-dimensional images in Figures 7(a) and (b), respectively.
Membership function of tracking error.

Three-dimensional images of fuzzy rules.

Input and output scaling parameters are adjusted based on actual conditions. By combining FGC with DFFC, an integrated control strategy is constructed, as shown in Figure 8. DFFC mitigates the impact of the system’s dynamic characteristics on control accuracy, while FGC can suppress wave disturbances. Introducing fuzzy rules makes the system less sensitive to input variations and disturbances during the adjustment of the PI parameters. Thus, better robustness can be achieved.
 $K_{\textrm{in}1}$
and
 $K_{\textrm{in}2}$
represent the tracking error
 $e$
and its derivative
 $de$
, while
 $K_{\textrm{out}1}$
and
 $K_{\textrm{out}2}$
represent
 $\Delta K_{p}$
and
 $\Delta K_{i}$
, respectively.
Comprehensive model of FGC and DFFC.

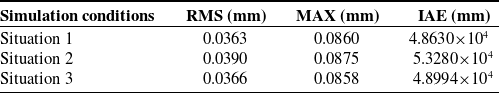
The DFFC plus FGC for one limb are simulated using the trajectory as described in Section 3.1 as the input and compared with DFFC plus the standard control loop, as shown in Figure 9. The FGC shows good adaptability and maintains excellent tracking performance even in the presence of disturbances. The root mean square error (RMS), maximum absolute value (MAX) and integral of absolute error (IAE) corresponding to different simulation conditions are calculated, as shown in Table II. Situations 1 and 2 represent the FGC under two conditions: without disturbance torque and with disturbance torque, respectively. Situation 3 represents DFFC plus FGC with disturbance torque. It is evident that all three indicators of tracking errors increase when the disturbance moment is considered. However, these indicators decrease when the DFFC is used. This indicates effective synergy between DFFC and FGC. In addition, the collaboration of FGC and DFFC reduces tracking errors when compared to the standard control loop with the original gain element.
Tracking errors under FGC.

Tracking errors under FGC.

To further demonstrate the robustness of the proposed approach, it is compared with the sliding mode control known for its excellent disturbance rejection capability. The sliding mode controller can be written as
 \begin{equation}u=\frac{-JL\varepsilon \textrm{sgn}(s)-JLc_{1}e_{2}-JLc_{2}e_{3}+JRe_{3}+JR\ddot{x_{1{t}}}+K_{{t}}\left(K_{{e}}+K_{\textrm{vfb}}\right)\left(e_{2}+\dot{x_{1{t}}}\right)+JL\dddot {x_{1{t}}}}{K_{{t}}}\end{equation}
where the output variable
 $u$
represents the motor voltage, and the input variables are the tracking error
 $e_{1}$
and its first and second derivatives
 $e_{2}$
,
 $e_{3}$
, as well as the first, second, and third derivatives of the desired trajectory
 $\dot{x_{1{t}}}$
,
 $\ddot{x_{1{t}}}$
,
 $\dddot {x_{1{t}}}$
.
 $\varepsilon$
,
 ${c}_{1}$
and
 ${c}_{2}$
are internal parameters of the controller.
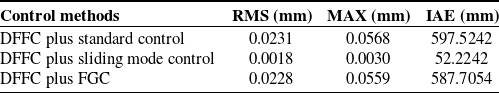
With the same input that is a multi-sine superposition curve shown in Figure 10(a), DFFC plus standard control loop with original gain element, DFFC plus sliding mode control, and DFFC plus FGC are simulated, respectively. When the external disturbance torque is not considered, the tracking errors of the three control methods are shown in Figure 10(b). The indicators of the tracking errors are shown in Table III. It can be observed that the sliding mode control combined with feedforward control achieves the smallest tracking error.
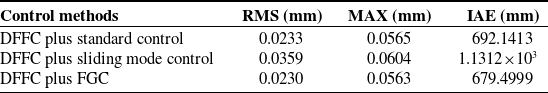
In practical application, the shipborne stabilisation platform is inevitably affected by disturbances due to unpredictable wave. Therefore, the external disturbance torques shown in Figure 11 are considered and the control methods are simulated again using the same input shown in Figure 10(a), as shown in Figure 12 and Table IV. One may see that after adding the external disturbance torque, the tracking errors corresponding to the sliding mode control increase significantly, while the FGC can still play a good role. The system model is needed for the sliding mode control, while it is not needed for the FGC. Therefore, it is recommended to prioritise the use of the FGC in combination with feedforward control.
Tracking errors without external disturbance torque.

Simulation figures without external disturbance torque.

External disturbance torque.

Thus, it can be concluded that the FGC exhibits strong adaptability even when an inaccurate model is used and disturbances exist. The integrated control strategy proposed in this paper exhibits strong adaptability across different operating conditions and application scenarios. The fuzzy inference process inherently provides input desensitisation, making the control action less sensitive to measurement noise and fluctuations typical of wave disturbances. This model-free approach provides FGC with exceptional adaptability and robustness against uncertainties and variations typical of the maritime environment, all without the computational burden or data requirements of complex adaptive or predictive controllers. Furthermore, the FGC proposed in this paper offers a significant practical advantage over conventional fuzzy controller implementations. In a conventional design, adapting the controller to different operating ranges or platforms would necessitate redesigning the membership functions and potentially the rule base to fit the new input/output universe of discourse. In contrast, we introduce input and output scaling modules in the fuzzy controller, which enable rapid adaptation simply by adjusting linear scaling factors (
 $K_{\textrm{in}1},\, K_{\textrm{in}2},\, K_{\textrm{out}1}$
and
 $K_{\textrm{out}2}$
in Figure 8). This eliminates the need for time-consuming re-tuning of the fuzzy logic controller, enhancing the controller’s adaptability and portability across different application scenarios.
4. Simulation and experimental verification
4.1. Overall platform simulation
In Section 3, the limb’s expected motion is directly specified to evaluate the tracking performance of the control methods for one limb system. Here, the control methods are studied on the shipborne stabilisation platform. To evaluate the controller’s performance under realistic sea conditions, the motion input to the lower platform (representing the ship’s disturbed motion) is calculated using Eq. (16) based on wave fluctuations. This calculated motion, depicted in Figure 2, serves as the measured values from the lower platform’s sensors and is applied throughout the simulation studies. In simulation, system employs double integration of measured acceleration to compute the pose changes of the lower platform and uses inverse kinematics to derive the desired motion trajectories for each limb.
Tracking errors with external disturbance torque.

RMS of tracking errors of different methods in simulation (mm).

Tracking errors with external disturbance torque.

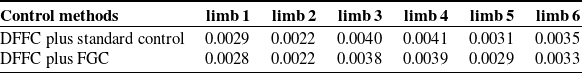
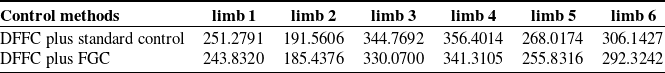
In the simulation condition, DFFC plus standard control loop with the original gain element, and DFFC plus FGC are simulated, respectively. The RMS and IAE indicators of the tracking errors for each limb under different control methods are compared, as shown in Tables V and VI. The results indicate that the FGC can reduce system tracking errors. Therefore, the designed control strategy can effectively stabilise the platform in the simulated environment.
IAE of tracking errors of different methods in simulation (mm).

4.2. Experimental verification
The experiments are conducted on a shipborne stabilisation platform with a 6-UPS mechanism at China State Shipbuilding Corporation Limited, as shown in Figure 13. The stabilisation platform is mounted on a large, heavy-load Stewart platform, which simulates the ship’s disturbed motion in wave environments. The experimental setup includes the Stewart platform, servo motors and drives, an IMU sensor, and a PC control terminal. The IMU sensor detects the pose variations of the lower platform.
Experimental setup.

In the experiment, the motion of the lower large Stewart platform consists of sinusoidal oscillations: an amplitude of 3 degrees about the x-axis and an amplitude of 2 degrees about the y-axis, with no motion in other degrees of freedom. The time histories of these commanded rotational angles are shown in Figure 14(a). The specific input profile was chosen to represent a significant and measurable disturbance for evaluating the controller’s stabilisation capabilities under laboratory conditions. The IMU sensor detects the pose changes of the lower platform, and the desired limb motion trajectories are calculated in real-time using inverse kinematics, as shown in Figure 14(b). Due to slight vibrations in the experimental environment during the lower platform’s movements, the desired limb trajectories also exhibit minor oscillations.
Input motion in experiment.

Tracking errors of different methods in the experiment.

In practical applications, the equipment is placed on the upper platform of the stabilisation platform and it is difficult to maintain a stable measurement environment. Therefore, the upper platform of the shipborne stabilisation platform is not equipped with sensors in the experiment. This limitation necessitates an indirect approach to evaluating the controller’s performance in stabilising the upper platform.
To address this issue, the primary performance metric adopted is the tracking error of the six limb lengths of the platform. The desired limb length trajectories, shown in Figure 14(b), are computed by assuming the upper platform is perfectly stable. Therefore, minimising the limb length tracking error directly reflects the controller’s success in counteracting disturbances and maintaining the desired upper platform pose. Consequently, a significant reduction in limb tracking error indicates a corresponding improvement in upper platform stabilisation accuracy.
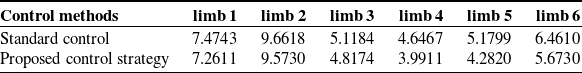
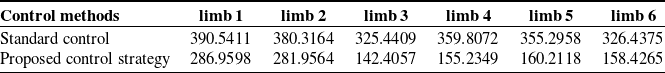
The parameters of the original gain algorithm in the standard control loop of the PMAC card are adjusted to a precision of two decimal places. The parameters that yield the smallest average tracking error over multiple experiments are selected as optimal. The standard control with optimal parameters is then compared with the proposed control strategy. As shown in Figure 15, the proposed control strategy significantly reduces the peak values and fluctuations of the tracking errors for the six limbs. Additionally, Tables VII and VIII show the RMS and MAX indicators, which demonstrate that the proposed strategy outperforms the standard control with optimal parameters. Specifically, the proposed control strategy reduces the RMS of the tracking error for each limb by an average of 8.88% and the MAX error by an average of 45.31% compared to the standard control with optimal parameters. These substantial reductions in limb tracking error show that the proposed control strategy effectively stabilises the upper platform.
While direct measurement is unavailable, the upper platform’s pose is also estimated through iterative forward kinematics calculations based on the measured lower platform’s pose and the limb lengths, as shown in Figure 16. It should be noted that any inaccuracies in the kinematic model or measurement noise would propagate into the estimated pose. Here,
 $x$
,
 $y$
, and
 $z$
represent the position coordinates of the upper platform’s centre of mass in the lower platform’s coordinate system, while
 $\alpha$
,
 $\beta$
, and
 $\gamma$
denote its orientation angles. This calculation is accurate given precise limb length and lower platform pose measurements, assuming ideal joint kinematics and rigid links.
RMS of tracking errors of different methods in experiment (
 $\mu$
m).

RMS of tracking errors of different methods in experiment (
 $\mu$
m).

Upper platform pose of different methods in the experiment.

The lower platform rotates around the x-axis and y-axis following a sine curve, while other pose parameters remain unchanged. Consequently, the
 $\alpha$
and
 $\beta$
angles of the upper platform also exhibit a sinusoidal behaviour. To prevent excessive limb extension or contraction, the posture adjustment strategy (outside the scope of this study) prioritises stabilising the upper platform’s orientation, resulting in smaller variations in orientation angles and larger changes in position coordinates. Compared with the standard control with optimal parameters, the proposed control strategy reduces the RMS of
 $\alpha$
and
 $\beta$
by 4.55% and 8.33%, respectively. Thus, the proposed control strategy achieves superior stabilisation performance, resulting in smaller orientation changes for the upper platform and better meeting the control requirements of the shipborne stabilisation platform.
5. Conclusion
This paper proposes an integrated control strategy that combines FGC with DFFC for shipborne stabilisation platforms facing unpredictable wave disturbances. The DFFC compensates for dynamic disturbances, while the FGC mitigates the impact of wave disturbances. The advantage of this strategy lies in its independence from both an accurate mathematical model and pre-training, allowing it to adjust parameters in real-time based on operating conditions, and its scaling modules facilitate adaptation to diverse operating conditions. Simulation results indicate that the proposed strategy can reduce system tracking errors. Experimental results demonstrate that compared to the standard control with optimal parameters, the proposed strategy reduces the RMS of limb tracking errors by 8.88% and the MAX by 45.31%. Concurrently, the orientation variation angles
 $\alpha$
and
 $\beta$
of the upper platform decrease by 4.55% and 8.33%, respectively. Both simulations and experiments confirm that this strategy improves control accuracy while maintaining high robustness and broad applicability.
Author contribution
Jiayue Zhang and Hengchun Cui conceived and designed the study. Jiayue Zhang conducted data gathering and performed statistical analyses. Jiayue Zhang, along with Jun Wu, wrote the original draft of the article. Jun Wu and Yanling Tian were involved in the review and editing of the manuscript. Jun Wu provided supervision and project administration and was responsible for funding acquisition.
Financial support
This work is supported by the National Natural Science Foundation of China (Grant Nos. U23B20103 and 52375502) and EU H2020 MSCA R&I Programme (no. 101022696).
Competing interests
The authors declare that they have no known competing financial interests or personal relationships that could have appeared to influence the work reported in this paper.
Ethical approval
Not applicable.