


1. Introduction
Multi-symplectic equations for Hamiltonian systems with two or more independent variables
 $x^{{\it\alpha}}$
have been developed as a useful extension of Hamiltonian systems with one evolution variable
 $t$
. This development has connections with dual variational formulations of travelling wave problems (e.g. Bridges Reference Bridges1992), and is useful in numerical schemes for Hamiltonian systems. Bridges and co-workers used the multi-symplectic approach to study linear and nonlinear wave propagation, generalizations of wave action, wave modulation theory and wave stability problems (Bridges Reference Bridges1997a
,Reference Bridges
b
). Bridges & Reich (Reference Bridges and Reich2006) developed multi-symplectic difference schemes. Multi-symplectic Hamiltonian systems have been studied by Marsden & Shkoller (Reference Marsden and Shkoller1999), Bridges, Hydon & Reich (Reference Bridges, Hydon and Reich2005), Bridges (Reference Bridges2006) and Bridges, Hydon & Lawson (Reference Bridges, Hydon and Lawson2010). Webb et al. (Reference Webb, McKenzie, Mace, Ko and Zank2007, Reference Webb, Ko, Mace, McKenzie and Zank2008, Reference Webb, Burrows, Ao and Zank2014d
) discussed travelling waves in multi-fluid plasmas using a multi-symplectic formulation. Holm, Marsden & Ratiu (Reference Holm, Marsden and Ratiu1998) gave an overview of Hamiltonian systems, semi-direct product Lie algebras and Euler–Poincaré equations.
Cotter, Holm & Hydon (Reference Cotter, Holm and Hydon2007) developed a multi-symplectic, Euler–Poincaré formulation of fluid mechanics. They showed that multi-symplectic ideal fluid mechanics type systems are related to Clebsch variable formulations in which the Lagrange multipliers play the role of canonically conjugate momenta to the constrained variables. Thus, the Clebsch variable formulation involves a momentum map.
The main aim of the present paper is to correct and extend the analysis of the multi-symplectic MHD equations derived by Webb, McKenzie & Zank (Reference Webb, McKenzie and Zank2014c ). Section 2 describes the MHD equations and the first law of thermodynamics. An overview of the key equations of the multi-symplectic MHD equations obtained by Webb et al. (Reference Webb, McKenzie and Zank2014c ) is given in § 3. We correct some typographical errors and present a more consistent description of the Cartan–Poincaré form for the system (§ 4). The Cartan–Poincaré form is used to obtain a set of differential forms representing the system using Cartan’s geometric theory of partial differential equations.
Section 5 concludes with a summary and discussion.
2. The model
The magnetohydrodynamic equations are:
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\rho}}{\partial t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }({\it\rho}\boldsymbol{u})=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial }{\partial t}({\it\rho}\boldsymbol{u})+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\left[{\it\rho}\boldsymbol{u}\boldsymbol{u}+\left(p+\frac{B^{2}}{2{\it\mu}_{0}}\right)\boldsymbol{I}-\frac{\boldsymbol{B}\boldsymbol{B}}{{\it\mu}_{0}}\right]=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial S}{\partial t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}S=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial \boldsymbol{B}}{\partial t}-\boldsymbol{{\rm\nabla}}\times (\boldsymbol{u}\times \boldsymbol{B})+\boldsymbol{u}\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B}=0, & \displaystyle\end{eqnarray}$$
 ${\it\rho}$
,
 $\boldsymbol{u}$
,
 $p$
,
 $S$
and
 $\boldsymbol{B}$
are the gas density, fluid velocity, pressure, specific entropy and magnetic induction
 $\boldsymbol{B}$
, respectively, and
 $\boldsymbol{I}$
is the unit
 $3\times 3$
dyadic. The gas pressure
 $p=p({\it\rho},S)$
is a function of the density
 ${\it\rho}$
and entropy
 $S$
, and
 ${\it\mu}_{0}$
is the magnetic permeability. Equations (2.1) and (2.2) are the mass and momentum conservation laws, (2.3) is the entropy advection equation and (2.4) is Faraday’s equation in the MHD limit. In classical MHD, (2.1)–(2.4) are supplemented by Gauss’ law:
 $$\begin{eqnarray}\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B}=0,\end{eqnarray}$$
which implies the non-existence of magnetic monopoles. The MHD equations are closed by specifying an equation of state for the gas
 $U=U({\it\rho},S)$
where
 $U({\it\rho},S)$
is the internal energy per unit mass. The first law of thermodynamics has the form:
 $$\begin{eqnarray}T\,\text{d}S=\text{d}Q=\text{d}U+p\,\text{d}{\it\tau}\quad \text{where }{\it\tau}=\frac{1}{{\it\rho}},\end{eqnarray}$$
where
 ${\it\tau}=1/{\it\rho}$
is the specific volume. Using the internal energy per unit volume
 ${\it\varepsilon}={\it\rho}U$
instead of
 $U$
, (2.6) may be written as:
 $$\begin{eqnarray}T\,\text{d}S=\frac{1}{{\it\rho}}(\text{d}{\it\varepsilon}-h\,\text{d}{\it\rho})\quad \text{where }h=\frac{{\it\varepsilon}+p}{{\it\rho}},\end{eqnarray}$$
is the enthalpy of the gas. Equation (2.8) gives the formulae:
 $$\begin{eqnarray}{\it\rho}T={\it\varepsilon}_{S},\quad h={\it\varepsilon}_{{\it\rho}},\quad p={\it\rho}{\it\varepsilon}_{{\it\rho}}-{\it\varepsilon},\end{eqnarray}$$
relating the temperature
 $T$
, enthalpy
 $h$
and pressure
 $p$
to the internal energy density
 ${\it\varepsilon}({\it\rho},S)$
. Here
 ${\it\varepsilon}_{S}=\partial {\it\varepsilon}/\partial S$
, and
 ${\it\varepsilon}_{{\it\rho}}=\partial {\it\varepsilon}/\partial {\it\rho}$
denote partial derivatives of
 ${\it\varepsilon}$
with respect to
 $S$
and
 ${\it\rho}$
.
3. Multi-symplectic approach
In this section we give a brief overview of the multi-symplectic formulation of MHD by Webb et al. (Reference Webb, McKenzie and Zank2014c ).
3.1. Clebsch variable action principle
Consider the MHD action (modified by constraints):
 $$\begin{eqnarray}J=\int \,\text{d}^{3}x\,\text{d}t\,L,\end{eqnarray}$$
where
 $$\begin{eqnarray}\displaystyle L & = & \displaystyle \left\{\frac{1}{2}{\it\rho}u^{2}-{\it\epsilon}({\it\rho},S)-\frac{B^{2}}{2{\it\mu}_{0}}\right\}+{\it\phi}\left(\frac{\partial {\it\rho}}{\partial t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }({\it\rho}\boldsymbol{u})\right)\nonumber\\ \displaystyle & & \displaystyle +\,{\it\beta}\left(\frac{\partial S}{\partial t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}S\right)+{\it\lambda}\left(\frac{\partial {\it\mu}}{\partial t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\it\mu}\right)\nonumber\\ \displaystyle & & \displaystyle +\,{\it\bf\Gamma}\boldsymbol{\cdot }\left(\frac{\partial \boldsymbol{B}}{\partial t}-\boldsymbol{{\rm\nabla}}\times (\boldsymbol{u}\times \boldsymbol{B})+\boldsymbol{u}(\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B})\right).\end{eqnarray}$$
In (3.2) the Lagrange multipliers
 ${\it\phi}$
,
 ${\it\beta}$
,
 ${\it\lambda}$
and
 ${\it\bf\Gamma}$
ensure that the mass, entropy, Lin constraint and Faraday’s equation are satisfied. Note we do not set
 $\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B}=0$
in our analysis. It can be set equal to zero after all variational calculations for the MHD system are completed. However, it does modify the Lagrange multiplier equation for
 ${\it\bf\Gamma}$
that ensures Faraday’s equation is satisfied (see Morrison & Greene (Reference Morrison and Greene1980, Reference Morrison and Greene1982), Morrison (Reference Morrison, Tabor and Treve1982), Holm & Kupershmidt (Reference Holm and Kupershmidt1983a
,Reference Holm and Kupershmidt
b
) and Chandre et al. (Reference Chandre, de Guillebon, Back, Tassi and Morrison2013) for further discussion of the MHD Poisson bracket). The Lagrangian in curly brackets equals the kinetic minus the potential energy (internal thermodynamic energy plus magnetic energy).
Stationary point conditions for the action are
 ${\it\delta}J=0$
.
 ${\it\delta}J/{\it\delta}\boldsymbol{u}=0$
gives the Clebsch representation for
 $\boldsymbol{M}={\it\rho}\boldsymbol{u}$
:
 $$\begin{eqnarray}\boldsymbol{M}={\it\rho}\boldsymbol{u}={\it\rho}\boldsymbol{{\rm\nabla}}{\it\phi}-{\it\beta}\boldsymbol{{\rm\nabla}}S-{\it\lambda}\boldsymbol{{\rm\nabla}}{\it\mu}+\boldsymbol{B}\times (\boldsymbol{{\rm\nabla}}\times {\it\bf\Gamma})-{\it\bf\Gamma}\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B}.\end{eqnarray}$$
Setting
 ${\it\delta}J/{\it\delta}{\it\phi}$
,
 ${\it\delta}J/{\it\delta}{\it\beta}$
,
 ${\it\delta}J/{\it\delta}{\it\lambda}$
and
 ${\it\delta}J/{\it\delta}{\it\bf\Gamma}$
equal to zero gives the mass, entropy advection, Lin constraint and Faraday (magnetic flux conservation) constraint equations:
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle {\it\rho}_{t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }({\it\rho}\boldsymbol{u})=0,\\ \displaystyle S_{t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}S=0,\\ \displaystyle {\it\mu}_{t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\it\mu}=0,\\ \displaystyle \boldsymbol{B}_{t}-\boldsymbol{{\rm\nabla}}\times (\boldsymbol{u}\times \boldsymbol{B})+\boldsymbol{u}(\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B})=0.\end{array}\!\!\!\right\} & & \displaystyle\end{eqnarray}$$
Similarly, setting
 ${\it\delta}J/{\it\delta}{\it\rho}$
,
 ${\it\delta}J/{\it\delta}S$
,
 ${\it\delta}J/{\it\delta}{\it\mu}$
and
 ${\it\delta}J/{\it\delta}\boldsymbol{B}$
equal to zero gives the evolution equations for the Clebsch potentials
 ${\it\phi}$
,
 ${\it\beta}$
,
 ${\it\lambda}$
and
 ${\it\bf\Gamma}$
as:
 $$\begin{eqnarray}\displaystyle & \displaystyle -\!\left(\frac{\partial {\it\phi}}{\partial t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\it\phi}\right)+\frac{1}{2}u^{2}-h=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\beta}}{\partial t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }({\it\beta}\boldsymbol{u})+{\it\rho}T=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\lambda}}{\partial t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }({\it\lambda}\boldsymbol{u})=0, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\partial {\it\bf\Gamma}}{\partial t}-\boldsymbol{u}\times (\boldsymbol{{\rm\nabla}}\times {\it\bf\Gamma})+\boldsymbol{{\rm\nabla}}({\it\bf\Gamma}\boldsymbol{\cdot }\boldsymbol{u})+\frac{\boldsymbol{B}}{{\it\mu}_{0}}=0. & \displaystyle\end{eqnarray}$$
 $\boldsymbol{{\rm\nabla}}({\it\bf\Gamma}\boldsymbol{\cdot }\boldsymbol{u})$
term in (3.8) is associated with
 $\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B}\neq 0$
.
3.2. Multi-symplectic approach
From Webb et al. (Reference Webb, McKenzie and Zank2014c ), the MHD system was written in the multi-symplectic form:
 $$\begin{eqnarray}\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}\frac{\partial z^{j}}{\partial x^{{\it\alpha}}}=\frac{\partial H}{\partial z^{i}},\end{eqnarray}$$
where the variables
 $z^{j}$
are defined as:
 $$\begin{eqnarray}\boldsymbol{z}=(u^{1},u^{2},u^{3},{\it\rho},S,{\it\mu},B^{1},B^{2},B^{3},{\it\Gamma}^{1},{\it\Gamma}^{2},{\it\Gamma}^{3},{\it\lambda},{\it\beta},{\it\phi})^{\text{T}}.\end{eqnarray}$$
The variables:
 $x^{{\it\alpha}}=(t,x,y,z)$
are the independent space and time variables, i.e.
 $x^{0}=t$
,
 $x^{1}=x$
,
 $x^{2}=y$
,
 $x^{3}=z$
. Below, we use the notation
 $z_{,{\it\alpha}}^{s}=\partial z^{s}/\partial x^{{\it\alpha}}$
. The constrained Lagrangian
 $L$
in (3.2) is written in the form:
 $$\begin{eqnarray}L=L_{0}+\mathop{\sum }_{s}L_{s}^{{\it\alpha}}z_{,{\it\alpha}}^{s},\end{eqnarray}$$
where
 $$\begin{eqnarray}L_{0}=\frac{1}{2}{\it\rho}u^{2}-{\it\varepsilon}({\it\rho},S)-\frac{B^{2}}{2{\it\mu}_{0}},\end{eqnarray}$$
is the unconstrained Lagrangian. The
 $L_{s}^{{\it\alpha}}(z)$
coefficients in (3.11) are the derivative coefficients in (3.2).
The multi-symplectic Hamiltonian is given by the generalized Legendre transformation:
 $$\begin{eqnarray}H(z)=\mathop{\sum }_{s}L_{s}^{{\it\alpha}}z_{,{\it\alpha}}^{s}-L=-L_{0}\equiv -\left(\frac{1}{2}{\it\rho}u^{2}-{\it\varepsilon}({\it\rho},S)-\frac{B^{2}}{2{\it\mu}_{0}}\right).\end{eqnarray}$$
The fundamental one-forms
 ${\it\omega}^{{\it\alpha}}$
(
 ${\it\alpha}=0,1,2,3$
) of the multi-symplectic system (3.9) are defined as:
 $$\begin{eqnarray}{\it\omega}^{{\it\alpha}}=L_{j}^{{\it\alpha}}(z)\,\text{d}z^{j}.\end{eqnarray}$$
Taking the exterior derivative of the
 ${\it\omega}^{{\it\alpha}}$
gives the formulae
 $$\begin{eqnarray}{\it\kappa}^{{\it\alpha}}=\text{d}{\it\omega}^{{\it\alpha}}={\textstyle \frac{1}{2}}\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}\,\text{d}z^{i}\wedge \text{d}z^{j},\end{eqnarray}$$
which, in turn, gives the formulae:
 $$\begin{eqnarray}\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}=\left(\frac{\partial L_{j}^{{\it\alpha}}}{\partial z^{i}}-\frac{\partial L_{i}^{{\it\alpha}}}{\partial z^{j}}\right),\end{eqnarray}$$
for the skew symmetric matrices in (3.9).
For the variables
 $z^{j}$
in (3.10) the one-forms
 ${\it\omega}^{{\it\alpha}}$
are given by:
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle {\it\omega}^{0}={\it\phi}\,\text{d}{\it\rho}+{\it\beta}\,\text{d}S+{\it\lambda}\,\text{d}{\it\mu}+{\it\bf\Gamma}\boldsymbol{\cdot }\text{d}\boldsymbol{B},\\ \displaystyle {\it\omega}^{i}=u^{i}({\it\beta}\,\text{d}S+{\it\lambda}\,\text{d}{\it\mu}+{\it\phi}\,\text{d}{\it\rho})+{\it\rho}{\it\phi}\,\text{d}u^{i}+{\it\bf\Gamma}\boldsymbol{\cdot }\boldsymbol{B}\,\text{d}u^{i}-B^{i}({\it\bf\Gamma}\boldsymbol{\cdot }\text{d}\boldsymbol{u})+u^{i}({\it\bf\Gamma}\boldsymbol{\cdot }\text{d}\boldsymbol{B}),\end{array}\!\!\!\right\}\qquad & & \displaystyle\end{eqnarray}$$
where
 $1\leqslant i\leqslant 3$
.
The pullback conservation laws:
 $$\begin{eqnarray}G_{{\it\beta}}=D_{{\it\alpha}}(L_{j}^{{\it\alpha}}(z)z_{,{\it\beta}}^{j}-L{\it\delta}_{{\it\beta}}^{{\it\alpha}})=0,\end{eqnarray}$$
follow from the pullback of the identities:
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle (L_{j}^{{\it\alpha}}\,\text{d}z^{j})_{,{\it\alpha}}=\text{d}\{L_{j}^{{\it\alpha}}(z)z_{,{\it\alpha}}^{j}-H(z)\}=\text{d}L,\\ \displaystyle (L_{j}^{{\it\alpha}}\,\text{d}z^{j})_{,{\it\alpha}}=(L_{j}^{{\it\alpha}}z_{,{\it\beta}}^{j}\,\text{d}x^{{\it\beta}})_{,{\it\alpha}}=(L_{j}^{{\it\alpha}}z_{,{\it\beta}}^{j})_{,{\it\alpha}}\,\text{d}x^{{\it\beta}}=\text{d}L=\frac{\partial L^{{\it\alpha}}}{\partial x^{{\it\beta}}}\,\text{d}x^{{\it\beta}}.\end{array}\!\!\!\right\} & & \displaystyle\end{eqnarray}$$
(see Proposition 4.1 of Webb et al. (Reference Webb, McKenzie and Zank2014c ) for more detail).
The pullback equation
 ${\it\kappa}_{,{\it\alpha}}^{{\it\alpha}}=0$
where
 ${\it\kappa}^{{\it\alpha}}=\text{d}{\it\omega}^{{\it\alpha}}$
gives rise to the symplecticity or phase-space conservation laws (structural conservation laws):
 $$\begin{eqnarray}D_{{\it\alpha}}(\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}z_{,{\it\beta}}^{i}z_{,{\it\gamma}}^{j})=0,\quad {\it\beta}<{\it\gamma}.\end{eqnarray}$$
These conservation laws can also be written in the form:
 $$\begin{eqnarray}D_{{\it\beta}}G_{{\it\gamma}}-D_{{\it\gamma}}G_{{\it\beta}}=D_{{\it\alpha}}(\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}z_{,{\it\beta}}^{i}z_{,{\it\gamma}}^{j})=0,\end{eqnarray}$$
i.e. the symplecticity conservation laws (3.21) are compatibility conditions for the pullback conservation laws (3.18).
The pullback conservation law (3.18) for
 ${\it\beta}=0$
(Webb et al.
Reference Webb, McKenzie and Zank2014c
, equation (5.39)) reduces to the energy conservation law:
 $$\begin{eqnarray}G_{0}=-\left\{\frac{\partial }{\partial t}\left(\frac{1}{2}{\it\rho}u^{2}+{\it\varepsilon}({\it\rho},S)+\frac{B^{2}}{2{\it\mu}_{0}}\right)+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\left({\it\rho}\boldsymbol{u}\left(\frac{1}{2}u^{2}+h\right)+\frac{\boldsymbol{E}\times \boldsymbol{B}}{{\it\mu}_{0}}\right)\right\}=0,\vphantom{\mathop{\sum }_{\sum }}\end{eqnarray}$$
where
 $h=({\it\varepsilon}+p)/{\it\rho}$
is the enthalpy of the gas,
 $\boldsymbol{E}=-\boldsymbol{u}\times \boldsymbol{B}$
is the electric field and
 $\boldsymbol{E}\times \boldsymbol{B}/{\it\mu}_{0}$
is the Poynting flux. Similarly, the pullback conservation laws (3.18) for
 ${\it\beta}=i\;(1\leqslant i\leqslant 3)$
give rise to the MHD momentum conservation equation:
 $$\begin{eqnarray}G^{i}=-\!\left\{\frac{\partial }{\partial t}({\it\rho}\boldsymbol{u})+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\left[{\it\rho}\boldsymbol{u}\otimes \boldsymbol{u}+\left(p+\frac{B^{2}}{2{\it\mu}_{0}}\right)\boldsymbol{I}-\frac{\boldsymbol{B}\otimes \boldsymbol{B}}{{\it\mu}_{0}}\right]\right\}^{i}=0,\end{eqnarray}$$
(Webb et al. (Reference Webb, McKenzie and Zank2014c ), equation (5.41)).
4. Extensions, comments and corrections
The symplecticity conservation laws (3.20)–(3.21) have a generalized curl form. Consider the symplecticity laws (3.21) for
 $1\leqslant i,k\leqslant 3$
, namely:
 $$\begin{eqnarray}{\it\Omega}_{ik}=D_{i}G_{k}-D_{k}G_{i}=0.\end{eqnarray}$$
Introduce the dual of the tensor
 ${\it\Omega}_{ik}$
defined as:
 $$\begin{eqnarray}V^{p}=-{\textstyle \frac{1}{2}}{\it\varepsilon}_{pik}{\it\Omega}_{ik}=-(\boldsymbol{{\rm\nabla}}\times \boldsymbol{G})^{p},\end{eqnarray}$$
where
 $\boldsymbol{{\rm\nabla}}\times \boldsymbol{G}$
is the spatial curl of
 $\boldsymbol{G}$
. Taking into account the momentum conservation law (3.23) for
 $\boldsymbol{G}$
, (4.2) reduces to:
 $$\begin{eqnarray}\boldsymbol{{\rm\nabla}}\times \boldsymbol{G}=-\left\{\frac{\partial }{\partial t}\boldsymbol{{\rm\nabla}}\times \boldsymbol{M}+\boldsymbol{{\rm\nabla}}\times \left[\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\left(\boldsymbol{M}\otimes \boldsymbol{u}-\frac{\boldsymbol{B}\otimes \boldsymbol{B}}{{\it\mu}_{0}}\right)\right]\right\}=0,\end{eqnarray}$$
where
 $$\begin{eqnarray}\boldsymbol{M}={\it\rho}\boldsymbol{u},\end{eqnarray}$$
is the momentum density or mass flux
 $\boldsymbol{M}$
of the MHD fluid. Note there is no contribution from the magnetic pressure (
 $B^{2}/(2{\it\mu}_{0})$
) and gas pressure (
 $p$
) gradient force terms in (4.3) because
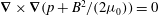 $\boldsymbol{{\rm\nabla}}\times \boldsymbol{{\rm\nabla}}(p+B^{2}/(2{\it\mu}_{0}))=0$
when one takes the curl of the momentum equation (3.23). The evolution of
 $\boldsymbol{{\rm\nabla}}\times \boldsymbol{M}$
in (4.3) is thus determined by the inertia and magnetic tension components:
 $$\begin{eqnarray}\boldsymbol{M}\otimes \boldsymbol{u}-\frac{\boldsymbol{B}\otimes \boldsymbol{B}}{{\it\mu}_{0}},\end{eqnarray}$$
of the MHD stress–energy tensor. This suggests that (4.3) describes Alfvénic type disturbances, in which both fluid spin and magnetic tension forces are part of the dynamics. Equation (4.3) can also be expressed in the conservation law form:
 $$\begin{eqnarray}\frac{\partial }{\partial t}\boldsymbol{{\rm\nabla}}\times \boldsymbol{M}+\boldsymbol{{\rm\nabla}}_{s}\left[\boldsymbol{{\rm\nabla}}\times \left(\boldsymbol{M}u^{s}-\frac{\boldsymbol{B}B^{s}}{{\it\mu}_{0}}\right)\right]=0.\end{eqnarray}$$
Pressure gradient forces play no role in the vorticity-like conservation laws (4.3) and (4.6).
Example.
For simple and double Alfvén waves (e.g. Webb et al.
Reference Webb, Ratkiewicz, Brio, Zank, Winterhalter, Gosling, Habbal, Kurth and Neugebauer1996, Reference Webb, Hu, Dasgupta, Roberts and Zank2010, Reference Webb, Zank, Burrows and Ratkiewicz2011, Reference Webb, Hu, Dasgupta and Zank2012),
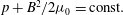 $p+B^{2}/2{\it\mu}_{0}=\text{const}.$
so that the momentum conservation equation (3.23) reduces to the form:
 $$\begin{eqnarray}\frac{\partial \boldsymbol{M}}{\partial t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\left(\boldsymbol{M}\otimes \boldsymbol{u}-\frac{\boldsymbol{B}\otimes \boldsymbol{B}}{{\it\mu}_{0}}\right)=0.\end{eqnarray}$$
Simple and double phase Alfvén waves admit the integrals:
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle \boldsymbol{u}\pm \boldsymbol{V}_{A}=\boldsymbol{u}\pm \frac{\boldsymbol{B}}{\sqrt{{\it\mu}_{0}{\it\rho}}}=(V_{1},V_{2},V_{3})\equiv \boldsymbol{V}=\text{const}.,\\ \displaystyle p=c_{4},\quad {\it\rho}=c_{5},\quad p_{B}=\frac{B^{2}}{2{\it\mu}_{0}}=c_{6},\end{array}\!\!\!\right\} & & \displaystyle\end{eqnarray}$$
where
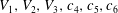 $V_{1},V_{2},V_{3},c_{4},c_{5},c_{6}$
are constants. In a simple MHD wave, the physical variables depend on a single phase function
 ${\it\varphi}(\boldsymbol{x},t)$
where
 ${\it\lambda}(\boldsymbol{n}({\it\varphi}))={\it\omega}/k$
is the phase speed of the wave,
 $\boldsymbol{n}({\it\varphi})=\boldsymbol{{\rm\nabla}}{\it\varphi}/|\boldsymbol{{\rm\nabla}}{\it\varphi}|$
is the wave normal, which is a given function of
 ${\it\varphi}$
such that
 $|\boldsymbol{n}|=1$
,
 $\boldsymbol{k}=\boldsymbol{{\rm\nabla}}{\it\varphi}$
is the wave vector of the wave and
 ${\it\omega}=-{\it\varphi}_{t}$
is the local frequency of the wave (note
 ${\it\lambda}(\boldsymbol{n})={\it\omega}/k$
) (see e.g. Boillat Reference Boillat1970; Webb et al.
Reference Webb, Ratkiewicz, Brio, Zank, Winterhalter, Gosling, Habbal, Kurth and Neugebauer1996, Reference Webb, Zank, Burrows and Ratkiewicz2011). A double MHD wave depends on two independent phase functions
 ${\it\varphi}_{1}(\boldsymbol{x},t)$
and
 ${\it\varphi}_{2}(\boldsymbol{x},t)$
(e.g. Grundland & Picard Reference Grundland and Picard2004; Webb et al.
Reference Webb, Hu, Dasgupta and Zank2012). The main point to note is that for simple and double Alfvén waves
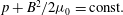 $p+B^{2}/2{\it\mu}_{0}=\text{const}.$
and
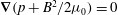 $\boldsymbol{{\rm\nabla}}(p+B^{2}/2{\it\mu}_{0})=0$
, which explains the absence of the
 $\boldsymbol{{\rm\nabla}}(p+B^{2}/2{\it\mu}_{0})$
in (4.7).
In the frame moving with velocity
 $\boldsymbol{V}=(V_{1},V_{2},V_{3})$
(the group velocity frame), the velocity of the fluid is:
 $$\begin{eqnarray}\tilde{\boldsymbol{u}}=\boldsymbol{u}-\boldsymbol{V}=\mp \boldsymbol{V}_{A}={\it\sigma}\boldsymbol{V}_{A},\quad {\it\sigma}=\mp 1.\end{eqnarray}$$
The momentum equation (4.7) in this frame reduces to:
 $$\begin{eqnarray}{\it\rho}\tilde{\boldsymbol{u}}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\tilde{\boldsymbol{u}}=\frac{\boldsymbol{B}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{B}}{{\it\mu}_{0}},\end{eqnarray}$$
which is a balance between the inertial force
 ${\it\rho}\tilde{\boldsymbol{u}}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\tilde{\boldsymbol{u}}$
and the magnetic tension force
 $\boldsymbol{B}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\boldsymbol{B}/{\it\mu}_{0}$
. In general, the magnetic field and fluid velocity rotate as one progresses through the wave. It is straightforward to verify (4.10) using the expression for
 $\tilde{\boldsymbol{u}}$
from (4.9). The generalized vorticity equation (4.3) clearly applies for general MHD flows. The above example illustrates (4.3) for the case of simple and double Alfvén waves.
The symplecticity conservation law (4.3) is different from that obtained by taking the curl of Euler’s momentum equation in the form
 $\text{d}\boldsymbol{u}/\text{d}t=\boldsymbol{F}$
where
 $\boldsymbol{F}$
is the net force on the fluid element, to obtain an equation for the evolution of the fluid vorticity
 ${\bf\omega}=\boldsymbol{{\rm\nabla}}\times \boldsymbol{u}$
. Webb et al. (Reference Webb, Dasgupta, McKenzie, Hu and Zank2014a
,Reference Webb, Dasgupta, McKenzie, Hu and Zank
b
) and Webb & Anco (Reference Webb and Anco2015) obtained a conservation law in ideal fluid mechanics (i.e. for
 $\boldsymbol{B}=0$
) for the generalized vorticity
 $$\begin{eqnarray}{\it\bf\Omega}={\bf\omega}+\boldsymbol{{\rm\nabla}}r\times \boldsymbol{{\rm\nabla}}S\quad \text{where }{\bf\omega}=\boldsymbol{{\rm\nabla}}\times \boldsymbol{u},\end{eqnarray}$$
is the fluid vorticity and
 $r$
satisfies the equation:
 $$\begin{eqnarray}\frac{\text{d}r}{\text{d}t}=\left(\frac{\partial }{\partial t}+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}\right)r=-T.\end{eqnarray}$$
Here
 $r={\it\beta}/{\it\rho}$
where
 ${\it\beta}$
is the Clebsch potential that ensures
 $\text{d}S/\text{d}t=0$
in the Eulerian, Clebsch variational approach (e.g. Zakharov & Kuznetsov Reference Zakharov and Kuznetsov1997) and
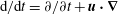 $\text{d}/\text{d}t=\partial /\partial t+\boldsymbol{u}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}$
is the Lagrangian time derivative following the flow. Webb et al. (Reference Webb, Dasgupta, McKenzie, Hu and Zank2014a
,Reference Webb, Dasgupta, McKenzie, Hu and Zank
b
) and Webb & Anco (Reference Webb and Anco2015) show that for fluid dynamics (
 $\boldsymbol{B}=0$
) the modified vorticity flux
 ${\it\bf\Omega}\boldsymbol{\cdot }\text{d}S$
is advected or Lie dragged with the flow, i.e.
 $$\begin{eqnarray}\frac{\text{d}}{\text{d}t}({\it\bf\Omega}\boldsymbol{\cdot }\text{d}S)=\left[\frac{\partial {\it\bf\Omega}}{\partial t}-\boldsymbol{{\rm\nabla}}\times (\boldsymbol{u}\times {\it\bf\Omega})+\boldsymbol{u}(\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }{\it\bf\Omega})\right]\boldsymbol{\cdot }\text{d}S=0.\end{eqnarray}$$
Tur & Yanovsky (Reference Tur and Yanovsky1993) and Webb et al. (Reference Webb, Dasgupta, McKenzie, Hu and Zank2014a
) derive a large class of conserved quantities that are Lie dragged with the flow. The conservation law (4.13) and the associated conservation law for the modified fluid helicity
 $\boldsymbol{u}\boldsymbol{\cdot }{\it\bf\Omega}$
are non-local conservation laws that depend on the non-local variable
 $r=-\!\int _{0}^{t}T(\boldsymbol{x},t)\,\text{d}t$
where the integration is with respect to the Lagrangian time
 $t$
(e.g. Webb et al.
Reference Webb, Dasgupta, McKenzie, Hu and Zank2014a
,Reference Webb, Dasgupta, McKenzie, Hu and Zank
b
). Conservation law (4.13) in fluid dynamics is analogous to Faraday’s equation in MHD. Note that
 $\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }{\it\bf\Omega}=0$
in (4.13).
The generalized fluid helicity conservation equation obtained by using (4.13) has the form:
 $$\begin{eqnarray}\frac{\partial }{\partial t}[{\it\bf\Omega}\boldsymbol{\cdot }(\boldsymbol{u}+r\boldsymbol{{\rm\nabla}}S)]+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\left[\boldsymbol{u}[{\it\bf\Omega}\boldsymbol{\cdot }(\boldsymbol{u}+r\boldsymbol{{\rm\nabla}}S)]+{\it\bf\Omega}\left(h-\frac{1}{2}|\boldsymbol{u}|^{2}\right)\right]=0.\end{eqnarray}$$
where
 $h$
is the enthalpy of the gas. This is a non-local conservation law as it depends on the non-local variable
 $r$
(
 $r$
satisfies (4.12)). In the case where
 $\boldsymbol{{\rm\nabla}}S=0$
, the conservation law reduces to the usual local fluid helicity conservation law. There is an analogous non-local conservation law for the generalized magnetic cross helicity for flows in which
 $\boldsymbol{{\rm\nabla}}S\neq 0$
, namely:
 $$\begin{eqnarray}\frac{\partial }{\partial t}[\boldsymbol{B}\boldsymbol{\cdot }(\boldsymbol{u}+r\boldsymbol{{\rm\nabla}}S)]+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\left[\boldsymbol{u}[\boldsymbol{B}\boldsymbol{\cdot }(\boldsymbol{u}+r\boldsymbol{{\rm\nabla}}S)]+\boldsymbol{B}\left(h-\frac{1}{2}|\boldsymbol{u}|^{2}\right)\right]=0.\end{eqnarray}$$
The derivation of (4.14) and (4.15) are given in Webb et al. (Reference Webb, Dasgupta, McKenzie, Hu and Zank2014a
,Reference Webb, Dasgupta, McKenzie, Hu and Zank
b
). Since the variable
 $r$
is obtained by integrating the temperature back along the fluid element trajectory with respect to the Lagrangian time
 $t$
, then the conservation laws (4.14) and (4.15) involve the memory of the past history of the fluid element.
There is another symplecticity conservation law obtained from (3.21) for the case
 ${\it\beta}=0$
and
 ${\it\gamma}=1,2,3$
. In that case (3.21) reduces to:
 $$\begin{eqnarray}\frac{\partial }{\partial t}\boldsymbol{G}-\boldsymbol{{\rm\nabla}}G_{0}=0,\end{eqnarray}$$
where
 $\boldsymbol{G}=0$
is the momentum equation (3.23) and
 $G_{0}=0$
is the energy conservation equation (3.22).
The general forms of the symplecticity equations for MHD using Eulerian Clebsch potentials were given in Webb et al. (Reference Webb, McKenzie and Zank2014c
) (equations (5.44) etc. of that paper). There were some typographical errors in the flux
 $F_{ab}^{k}$
, indicated below. The general symplecticity conservation laws obtained by Webb et al. (Reference Webb, McKenzie and Zank2014c
) have the form:
 $$\begin{eqnarray}\frac{\partial }{\partial t}(F_{ab}^{0})+\frac{\partial }{\partial x^{k}}(F_{ab}^{k})=0,\end{eqnarray}$$
where
 $$\begin{eqnarray}F_{ab}^{0}=\frac{\partial ({\it\phi},{\it\rho})}{\partial (x^{a},x^{b})}+\frac{\partial ({\it\beta},S)}{\partial (x^{a},x^{b})}+\frac{\partial ({\it\lambda},{\it\mu})}{\partial (x^{a},x^{b})}+\frac{\partial ({\it\Gamma}_{s},B^{s})}{\partial (x^{a},x^{b})},\end{eqnarray}$$
and
 $$\begin{eqnarray}\displaystyle F_{ab}^{k}\! & = & \displaystyle \!-\frac{\partial ({\it\rho}u^{k},{\it\phi})}{\partial (x^{a},x^{b})}+\frac{\partial ({\it\beta}u^{k},S)}{\partial (x^{a},x^{b})}+\frac{\partial ({\it\lambda}u^{k},{\it\mu})}{\partial (x^{a},x^{b})}\nonumber\\ \displaystyle & & \displaystyle +\,\frac{\partial ({\it\Gamma}_{s}B^{s},u^{k})}{\partial (x^{a},x^{b})}+\frac{\partial ({\it\Gamma}_{s}u^{k},B^{s})}{\partial (x^{a},x^{b})}-\frac{\partial ({\it\Gamma}_{s}B^{k},u^{s})}{\partial (x^{a},x^{b})}.\end{eqnarray}$$
In (4.19)
 $1\leqslant k\leqslant 3$
. The fourth term on the right-hand side of (4.19) was missed in (5.48) in Webb et al. (Reference Webb, McKenzie and Zank2014c
). Also in (4.19) we used the identity:
 $$\begin{eqnarray}\frac{\partial ({\it\phi}u^{k},{\it\rho})}{\partial (x^{a},x^{b})}+\frac{\partial ({\it\rho}{\it\phi},u^{k})}{\partial (x^{a},x^{b})}=-\frac{\partial ({\it\rho}u^{k},{\it\phi})}{\partial (x^{a},x^{b})},\end{eqnarray}$$
to simplify (5.48) of Webb et al. (Reference Webb, McKenzie and Zank2014c ). The derivation of the symplecticity conservation laws (4.3) and (4.16) using the general symplecticity laws (4.17) and using (3.3)–(3.8) is a non-trivial algebraic exercise.
4.1. Differential forms approach
Proposition 4.3 in Webb et al. (Reference Webb, McKenzie and Zank2014c
) contains flaws. The first statement in Proposition 4.3 of Webb et al. (Reference Webb, McKenzie and Zank2014c
) is correct, but it is not a variational statement. Equation (4.46) of Webb et al. (Reference Webb, McKenzie and Zank2014c
) is incorrect, i.e.
 ${\it\Omega}\neq \,\text{d}z^{{\it\mu}}\wedge {\it\beta}_{{\it\mu}}$
. Propositions 4.1 and 4.2 given below replace Proposition 4.3 of Webb et al. (Reference Webb, McKenzie and Zank2014c
). A consistent approach to the multi-symplectic equations using differential forms for 1-D Lagrangian gas dynamics was given by Webb (Reference Webb2015). Webb & Anco (Reference Webb and Anco2015) have given the corresponding theory for multi-dimensional, ideal, compressible, Lagrangian gas dynamics. Below we use differential forms to describe the Eulerian, Clebsch variable MHD variational principle of Webb et al. (Reference Webb, McKenzie and Zank2014c
).
Proposition 4.1. The multi-symplectic system (3.9) is a stationary point of the action:
 $$\begin{eqnarray}J=\int {\it\psi}^{\ast }({\it\Theta})=\int L\,\text{d}V,\end{eqnarray}$$
where
 ${\it\psi}^{\ast }({\it\Theta})$
is the pullback of the differential form
 ${\it\Theta}$
given below, namely:
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle {\it\Theta}={\it\omega}^{{\it\alpha}}\wedge \text{d}\tilde{x}^{{\it\alpha}}-H\,\text{d}V,\quad {\it\omega}^{{\it\alpha}}=L_{j}^{{\it\alpha}}\,\text{d}z^{j},\\ \displaystyle \text{d}V=\text{d}t\wedge \text{d}x\wedge \text{d}y\wedge \text{d}z,\\ \displaystyle \text{d}\tilde{x}^{{\it\alpha}}=\partial _{{\it\alpha}}\lrcorner \,\text{d}V\equiv (-1)^{{\it\alpha}}\,\text{d}x_{0}\wedge \cdots \text{d}x^{{\it\alpha}-1}\wedge \text{d}x^{{\it\alpha}+1}\cdots \wedge \text{d}x^{n},\end{array}\!\!\!\right\} & & \displaystyle\end{eqnarray}$$
where we use the notation
 $(x^{0},x^{1},x^{2},x^{3})=(t,x,y,z)$
, and
 $L$
is the constrained Lagrangian (3.2).
Proof. The pullback of the form
 ${\it\Theta}$
is given by:
 $$\begin{eqnarray}\displaystyle {\it\psi}^{\ast }({\it\Theta})\! & = & \displaystyle \!{\it\psi}^{\ast }(L_{j}^{{\it\alpha}}\,\text{d}z^{j}\wedge \text{d}\tilde{x}_{{\it\alpha}}-H\,\text{d}V)\nonumber\\ \displaystyle \! & = & \displaystyle \!L_{j}^{{\it\alpha}}\frac{\partial z^{j}}{\partial x^{s}}\,\text{d}x^{s}\wedge \text{d}\tilde{x}^{{\it\alpha}}-H\,\text{d}V.\end{eqnarray}$$
However,
 $$\begin{eqnarray}\text{d}x^{s}\wedge \text{d}\tilde{x}_{{\it\alpha}}=\text{d}x^{s}\wedge (-1)^{{\it\alpha}}\,\text{d}x^{0}\cdots \wedge \text{d}x^{{\it\alpha}-1}\wedge \text{d}x^{{\it\alpha}+1}\cdots \wedge \text{d}x^{n}\equiv (-1)^{2{\it\alpha}}{\it\delta}_{{\it\alpha}}^{s}\,\text{d}V.\end{eqnarray}$$
Thus,
 $$\begin{eqnarray}{\it\psi}^{\ast }({\it\Theta})=\left(L_{j}^{{\it\alpha}}\frac{\partial z^{j}}{\partial x^{{\it\alpha}}}-H\right)\,\text{d}V\equiv L\,\text{d}V,\end{eqnarray}$$
where
 $L$
is the multi-symplectic Lagrangian (3.10).
The stationary point conditions,
 ${\it\delta}J/{\it\delta}z^{i}=0$
, give the Euler–Lagrange equations:
 $$\begin{eqnarray}\frac{{\it\delta}J}{{\it\delta}z^{i}}=\frac{\partial L}{\partial z^{i}}-\frac{\partial }{\partial x^{j}}\left(\frac{\partial L}{\partial z_{,j}^{i}}\right)=\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}\frac{\partial z^{j}}{\partial x^{{\it\alpha}}}-\frac{\partial H}{\partial z^{i}}=0,\end{eqnarray}$$
which is the multi-symplectic system (3.9) (see also Hydon Reference Hydon2005).
Proposition 4.2. Consider the variational functional:
 $$\begin{eqnarray}G[{\it\Omega}]=\int _{M}{\it\Omega},\end{eqnarray}$$
where
 $$\begin{eqnarray}{\it\Omega}=\text{d}{\it\Theta}=\text{d}{\it\omega}^{{\it\alpha}}\wedge \text{d}\tilde{x}_{{\it\alpha}}-\text{d}H\wedge \text{d}V,\end{eqnarray}$$
and
 $M$
is a region of the jet space (fibre bundle space) with boundary
 $\partial M$
, in which the
 $z^{s}$
are taken as independent of the base variables
 $x^{{\it\alpha}}\;({\it\alpha}=0,1,2,3)$
. Consider the variational principle:
 $$\begin{eqnarray}{\it\delta}G[{\it\Omega}]=\int _{M}{\mathcal{L}}_{\boldsymbol{V}}({\it\Omega})=0,\end{eqnarray}$$
where
 $$\begin{eqnarray}{\mathcal{L}}_{\boldsymbol{V}}=\frac{\text{d}}{\text{d}{\it\epsilon}}=V^{i}\frac{\partial }{\partial z^{i}},\end{eqnarray}$$
is the Lie derivative with respect to the arbitrary, but smooth vector field
 $\boldsymbol{V}$
. The variational equation
 ${\it\delta}G[{\it\Omega}]=0$
reduces to:
 $$\begin{eqnarray}{\it\delta}G[{\it\Omega}]=\int _{\partial M}V^{p}{\it\beta}_{p}=0,\end{eqnarray}$$
where the forms
 ${\it\beta}_{p}$
are given by the formulae:
 $$\begin{eqnarray}{\it\beta}_{p}=\frac{\partial }{\partial z^{p}}\lrcorner {\it\Omega}=\unicode[STIX]{x1D612}_{pj}^{\,{\it\alpha}}\,\text{d}z^{j}\wedge \text{d}\tilde{x}_{{\it\alpha}}-\frac{\partial H}{\partial z^{p}}\,\text{d}V.\end{eqnarray}$$
(
 $1\leqslant p\leqslant N$
). Because the
 $V^{p}$
are arbitrary smooth functions of the
 $z^{s}$
, the variational principle
 ${\it\delta}G[{\it\Omega}]=0$
implies:
 $$\begin{eqnarray}{\it\beta}_{p}=0,\quad 1\leqslant p\leqslant N.\end{eqnarray}$$
The pullback of the forms
 $\{{\it\beta}_{p}\}$
to the base manifold gives the equations:
 $$\begin{eqnarray}\tilde{{\it\beta}}_{p}=\left(\unicode[STIX]{x1D612}_{pj}^{\,{\it\alpha}}\frac{\partial z^{j}}{\partial x^{{\it\alpha}}}-\frac{\partial H}{\partial z^{p}}\right)\,\text{d}V=0.\end{eqnarray}$$
Thus, the sectioned forms
 $\tilde{{\it\beta}}_{p}$
vanish on the solution manifold of the multi-symplectic system (3.9), and the
 $\{{\it\beta}_{p}\}$
can be used as a basis of Cartan forms describing the system (3.9).
Proof. The proof is essentially the same as that given by Webb (Reference Webb2015) for the case of 1-D gas dynamics. A critical component of the proof is the use of Cartan’s magic formula:
 $$\begin{eqnarray}{\mathcal{L}}_{\boldsymbol{V}}({\it\Omega})=\boldsymbol{V}\lrcorner \,\text{d}{\it\Omega}+\text{d}(\boldsymbol{V}\lrcorner {\it\Omega})=\text{d}(\boldsymbol{V}\lrcorner {\it\Omega}),\end{eqnarray}$$
where we used the facts
 ${\it\Omega}=\text{d}{\it\Theta}$
and
 $\text{d}{\it\Omega}=\text{d}\,\text{d}{\it\Theta}=0$
. Note that the Lie derivative with respect to a vector field
 $\boldsymbol{V}$
means the derivative along a curve, with tangent vector
 $\boldsymbol{V}$
in which
 ${\it\epsilon}$
refers to the parameter along the curve. Usually one has in mind a continuous group of transformations, in which
 ${\it\epsilon}=0$
corresponds to the identity transformation. We use the notation
 ${\mathcal{L}}_{\boldsymbol{V}}\equiv \text{d}/\text{d}{\it\epsilon}$
to denote the directional derivative along the curve with tangent vector
 $\boldsymbol{V}$
. Using (4.35) and Stokes theorem, (4.29) reduces to:
 $$\begin{eqnarray}{\it\delta}G[{\it\Omega}]=\int _{M}\,\text{d}(\boldsymbol{V}\lrcorner {\it\Omega})=\int _{\partial M}\boldsymbol{V}\lrcorner {\it\Omega}=\int _{\partial M}V^{p}\left(\frac{\partial }{\partial z^{p}}\lrcorner {\it\Omega}\right)=\int _{\partial M}V^{p}{\it\beta}_{p}=0,\end{eqnarray}$$
which verifies (4.31). The formula (4.32) for
 ${\it\beta}_{p}$
is obtained by using (3.15) for
 $\text{d}{\it\omega}^{{\it\alpha}}$
and (4.28) for
 ${\it\Omega}$
, to obtain:
 $$\begin{eqnarray}{\it\beta}_{p}=\frac{\partial }{\partial z^{p}}\lrcorner {\it\Omega}=\frac{\partial }{\partial z^{p}}\lrcorner \left(\frac{1}{2}\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}\,\text{d}z^{i}\wedge \text{d}z^{j}\wedge \text{d}\tilde{x}_{{\it\alpha}}-\frac{\partial H}{\partial z^{a}}\,\text{d}z^{a}\wedge \text{d}V\right).\end{eqnarray}$$
Using the skew symmetry of
 $\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}$
and
 $\text{d}z^{i}\wedge \text{d}z^{j}$
, (4.37) reduces to the expression (4.32) for
 ${\it\beta}_{p}$
. This completes the proof.
Remark.
The integrability conditions
 $\text{d}\,\text{d}{\it\omega}^{{\it\alpha}}=0$
imply the identities:
 $$\begin{eqnarray}\unicode[STIX]{x1D612}_{ij,k}^{\,{\it\alpha}}+\unicode[STIX]{x1D612}_{jk,i}^{\,{\it\alpha}}+\unicode[STIX]{x1D612}_{ki,j}^{\,{\it\alpha}}=0,\end{eqnarray}$$
where
 $\unicode[STIX]{x1D612}_{ij,k}^{\,{\it\alpha}}\equiv \partial \unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}/\partial z^{k}$
,
 $i\neq j\neq k$
,
 $1\leqslant i,j,k\leqslant N$
and
 $0\leqslant {\it\alpha}\leqslant 3$
. These identities are equivalent to the Jacobi identity in the case of finite dimensional, Hamiltonian systems in which there is only one evolution variable in which
 $\unicode[STIX]{x1D612}^{0}$
is invertible (Zakharov & Kuznetsov Reference Zakharov and Kuznetsov1997). They are equivalent to the requirement that the
 $L_{i}^{{\it\alpha}}$
have continuous second-order partial derivatives with respect to
 $z^{j}$
and
 $z^{k}$
, i.e.
 $(L_{i}^{{\it\alpha}})_{,j,k}=(L_{i}^{{\it\alpha}})_{,k,j}$
.
4.2. The differential forms
 ${\it\beta}_{p}$

The differential forms
 ${\it\beta}_{p}=\partial _{z^{p}}\lrcorner {\it\Omega}$
in (4.32) may be used to represent the MHD system described by the Clebsch variable variational principle. The dependent variables
 $\boldsymbol{z}$
are listed in (3.10). In the time evolution variational principle (e.g. Zakharov & Kuznetsov Reference Zakharov and Kuznetsov1997), the fluid velocity
 $\boldsymbol{u}$
is expressed in terms of the Clebsch potentials, and is eliminated from the Hamiltonian density
 $H=(1/2){\it\rho}u^{2}+{\it\varepsilon}({\it\rho},S)+B^{2}/(2{\it\mu}_{0})$
and
 $({\it\rho},{\it\phi})$
,
 $(S,{\it\beta})$
,
 $({\it\mu},{\it\lambda})$
,
 $(\boldsymbol{B},{\it\bf\Gamma})$
are canonically conjugate pairs in the canonical Poisson bracket. We use the notation:
 $$\begin{eqnarray}{\it\beta}^{z^{i}}=\partial _{z^{i}}\lrcorner {\it\Omega},\end{eqnarray}$$
where the Cartan–Poincaré form
 ${\it\Omega}$
in (4.28) has the form:
 $$\begin{eqnarray}{\it\Omega}=\text{d}{\it\omega}^{0}\wedge \text{d}\tilde{x}_{0}+\text{d}{\it\omega}^{k}\wedge \text{d}\tilde{x}_{k}-\frac{\partial H}{\partial z^{p}}\,\text{d}z^{p}\wedge \text{d}V,\end{eqnarray}$$
and the differential forms
 ${\it\omega}^{0}$
and
 ${\it\omega}^{k}$
are listed in (3.17). From (4.39) and (4.40)
 $$\begin{eqnarray}{\it\beta}^{z^{i}}=\partial _{z^{i}}\lrcorner \left\{\text{d}{\it\omega}^{0}\wedge \text{d}\tilde{x}_{0}+\text{d}{\it\omega}^{k}\wedge \text{d}\tilde{x}_{k}-\frac{\partial H}{\partial z^{p}}\,\text{d}z^{p}\wedge \text{d}V\right\}.\end{eqnarray}$$
Using (3.17) and (4.41) we obtain:
 $$\begin{eqnarray}{\it\beta}^{u^{i}}=({\it\beta}\,\text{d}S+{\it\lambda}\,\text{d}{\it\mu}-{\it\rho}\,\text{d}{\it\phi}-B^{s}\,\text{d}{\it\Gamma}_{s})\wedge \text{d}\tilde{x}_{i}+({\it\Gamma}_{i}\,\text{d}B^{k}+B^{k}\,\text{d}{\it\Gamma}_{i})\wedge \text{d}\tilde{x}_{k}+{\it\rho}u^{i}\,\text{d}V,\end{eqnarray}$$
for the differential forms associated with
 $\boldsymbol{u}$
. Using the identity
 $$\begin{eqnarray}\text{d}x^{a}\wedge \text{d}\tilde{x}_{i}={\it\delta}_{i}^{a}\,\text{d}V,\end{eqnarray}$$
the sectioned form equation
 $\tilde{{\it\beta}}^{u^{i}}=0$
yields the expression:
 $$\begin{eqnarray}{\it\rho}\boldsymbol{u}={\it\rho}\boldsymbol{{\rm\nabla}}{\it\phi}-{\it\beta}\boldsymbol{{\rm\nabla}}S-{\it\lambda}\boldsymbol{{\rm\nabla}}{\it\mu}+\boldsymbol{B}\boldsymbol{\cdot }(\boldsymbol{{\rm\nabla}}{\it\bf\Gamma})^{\text{T}}-\boldsymbol{B}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}{\it\bf\Gamma}-{\it\bf\Gamma}\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }\boldsymbol{B},\end{eqnarray}$$
which is equivalent to the Clebsch expansion for the mass flux
 ${\it\rho}\boldsymbol{u}$
given in (3.3).
The differential form
 ${\it\beta}^{{\it\rho}}$
is given by:
 $$\begin{eqnarray}{\it\beta}^{{\it\rho}}=\partial _{{\it\rho}}\lrcorner {\it\Omega}=(\partial _{{\it\rho}}\lrcorner \,\text{d}{\it\omega}^{0})\wedge \text{d}\tilde{x}_{0}+(\partial _{{\it\rho}}\lrcorner \,\text{d}{\it\omega}^{k})\wedge \text{d}\tilde{x}^{k}-\frac{\partial H}{\partial {\it\rho}}\,\text{d}V.\end{eqnarray}$$
Using (3.14) for
 $H$
, we obtain:
 $$\begin{eqnarray}\frac{\partial H}{\partial {\it\rho}}=-\left(\frac{1}{2}u^{2}-{\it\varepsilon}_{{\it\rho}}\right)=-\left(\frac{1}{2}u^{2}-h\right),\end{eqnarray}$$
where
 $h=({\it\varepsilon}+p)/{\it\rho}$
is the gas enthalpy. Substituting (4.46) in (4.45) gives
 $$\begin{eqnarray}\displaystyle & \displaystyle {\it\beta}^{{\it\rho}}=-(\text{d}{\it\phi}\wedge \text{d}\tilde{x}_{0}+u^{k}\,\text{d}{\it\phi}\wedge \text{d}\tilde{x}_{k})+({\textstyle \frac{1}{2}}u^{2}-h)\,\text{d}V, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \tilde{{\it\beta}}^{{\it\rho}}=-\!\left[\frac{\text{d}{\it\phi}}{\text{d}t}-\left(\frac{1}{2}u^{2}-h\right)\right]\,\text{d}V, & \displaystyle\end{eqnarray}$$
 ${\it\beta}^{{\it\rho}}$
and for the sectioned form
 $\tilde{{\it\beta}}^{{\it\rho}}$
. Note that
 $\tilde{{\it\beta}}^{{\it\rho}}=0$
is equivalent to Bernoulli’s equation (3.5). Similarly, we obtain:
 $$\begin{eqnarray}\displaystyle & \displaystyle {\it\beta}^{S}=\partial _{S}\lrcorner {\it\Omega}=-\text{d}{\it\beta}\wedge \text{d}\tilde{x}_{0}-\text{d}({\it\beta}u^{k})\wedge \text{d}\tilde{x}_{k}-{\it\rho}T\,\text{d}V, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \tilde{{\it\beta}}^{S}=-\!\left(\frac{\partial {\it\beta}}{\partial t}+\boldsymbol{{\rm\nabla}}\boldsymbol{\cdot }({\it\beta}\boldsymbol{u})+{\it\rho}T\right)\,\text{d}V. & \displaystyle\end{eqnarray}$$
 $\tilde{{\it\beta}}^{S}=0$
corresponds to (3.6) for
 ${\it\beta}$
.
Following the above procedure we obtain the equations:
 $$\begin{eqnarray}\displaystyle \left.\begin{array}{@{}c@{}}\displaystyle {\it\beta}^{{\it\mu}}=\partial _{{\it\mu}}\lrcorner {\it\Omega}=-[\text{d}{\it\lambda}\wedge \text{d}\tilde{x}_{0}+\text{d}({\it\lambda}u^{k})\wedge \text{d}\tilde{x}_{k}],\\ \displaystyle {\it\beta}^{B^{i}}=-\left[\text{d}{\it\Gamma}_{i}\wedge \text{d}\tilde{x}_{0}+u^{k}\,\text{d}{\it\Gamma}_{i}\wedge \text{d}\tilde{x}_{k}+{\it\Gamma}_{s}\,\text{d}u^{s}\wedge \text{d}\tilde{x}_{i}+\frac{B^{i}}{{\it\mu}_{0}}\,\text{d}V\right],\\ \displaystyle {\it\beta}^{{\it\Gamma}_{i}}=\text{d}B^{i}\wedge \text{d}\tilde{x}_{0}+(B^{i}\,\text{d}u^{k}+u^{k}\,\text{d}B^{i}-B^{k}\,\text{d}u^{i})\wedge \text{d}\tilde{x}_{k},\\ \displaystyle {\it\beta}^{{\it\lambda}}=\partial _{{\it\lambda}}\lrcorner {\it\Omega}=(\text{d}{\it\mu}\wedge \text{d}\tilde{x}_{0}+u^{k}\,\text{d}{\it\mu}\wedge \text{d}\tilde{x}_{k}),\\ \displaystyle {\it\beta}^{{\it\beta}}=\partial _{{\it\beta}}\lrcorner {\it\Omega}=\text{d}S\wedge \text{d}\tilde{x}_{0}+u^{k}\,\text{d}S\wedge \text{d}\tilde{x}_{k},\\ \displaystyle {\it\beta}^{{\it\phi}}=\partial _{{\it\phi}}\lrcorner {\it\Omega}=\text{d}{\it\rho}\wedge \text{d}\tilde{x}_{0}+(u^{k}\,\text{d}{\it\rho}+{\it\rho}\,\text{d}u^{k})\wedge \text{d}\tilde{x}_{k}.\end{array}\!\!\!\right\} & & \displaystyle\end{eqnarray}$$
The pullback of the above equations, i.e.
 $\tilde{{\it\beta}}^{z^{p}}=0$
, gives the evolution equations for
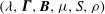 $({\it\lambda},{\it\bf\Gamma},\boldsymbol{B},{\it\mu},S,{\it\rho})$
listed in (3.4)–(3.8). The differential form equations
 ${\it\beta}^{z^{p}}=0$
thus represent the partial differential equation system (3.9).
It is not obvious that the system of forms
 $\{{\it\beta}^{z^{p}}\}$
above is a closed ideal. A check on the closure of the forms for the case of non-barotropic, 1-D gas dynamics (i.e.
 $\boldsymbol{B}=0$
) indicates that the ideal of forms
 ${\mathcal{I}}=\{{\it\beta}^{u},{\it\beta}^{{\it\rho}},{\it\beta}^{S},{\it\beta}^{{\it\beta}},{\it\beta}^{{\it\phi}}\}$
can be closed by adjoining the form
 $\text{d}{\it\beta}^{u}$
. The ideal
 ${\mathcal{I}}$
is closed for the case of a barotropic gas. The Cartan approach to Lie symmetries requires that
 ${\mathcal{I}}$
is a closed ideal (e.g. Harrison & Estabrook (Reference Harrison and Estabrook1971)). The ideal is closed if
 $\text{d}{\it\beta}_{i}=c_{ij}\wedge {\it\beta}^{z^{j}}$
, where the
 $c_{ij}$
are forms. It should be noted that the ideal of forms obtained by Webb (Reference Webb2015) for 1-D, Lagrangian, multi-symplectic gas dynamics is closed. The ideal of forms for multi-dimensional, Lagrangian, compressible gas dynamics obtained from the Cartan–Poincaré form is also a closed ideal (Webb & Anco Reference Webb and Anco2015). This suggests that the ideal of forms using the Clebsch variable description has a more complicated structure than the set of forms that arise in the Lagrangian variational approach. In general, this question requires more work and lies beyond the scope of the present paper.
5. Summary and concluding remarks
In this paper, we have corrected some flaws in the paper by Webb et al. (Reference Webb, McKenzie and Zank2014c
) on multi-symplectic MHD. This includes the correction of some typographic errors in the expressions for the conserved fluxes in the symplecticity conservation laws written in terms of the Clebsch potentials in (4.17)–(4.19), and in particular expression (4.19) for
 $F_{ab}^{k}$
has been corrected. We pointed out that the vorticity-type symplecticity conservation law is equivalent to taking the curl of the MHD momentum equation in the form (4.6). This conservation law has conserved density
 $\boldsymbol{{\rm\nabla}}\times \boldsymbol{M}$
where
 $\boldsymbol{M}={\it\rho}\boldsymbol{u}$
is the momentum density of the MHD fluid. Pressure gradient forces due to the combined gas and magnetic pressures (i.e.
 $\boldsymbol{{\rm\nabla}}(p+p_{B})$
, where
 $p_{B}=B^{2}/(2{\it\mu}_{0})$
is the magnetic pressure and
 $p$
is the gas pressure), play no role in this conservation law. The example of simple and double Alfvén waves was used to illustrate this conservation law (4.7)–(4.10). In simple and double Alfvén waves the total magnetic and gas pressure
 $p+B^{2}/2{\it\mu}_{0}$
is a constant. These solutions of the MHD equations exhibit fluid vorticity and non-zero electric current (
 $\boldsymbol{J}=\boldsymbol{{\rm\nabla}}\times \boldsymbol{B}/{\it\mu}_{0}\neq 0$
). This symplecticity conservation law is different than that obtained by Webb & Anco (Reference Webb and Anco2015) in ideal Lagrangian fluid mechanics. In the latter paper, the vorticity symplecticity conservation law involved
 ${\it\bf\Omega}={\bf\omega}+\boldsymbol{{\rm\nabla}}r\times \boldsymbol{{\rm\nabla}}S$
where
 ${\bf\omega}=\boldsymbol{{\rm\nabla}}\times \boldsymbol{u}$
is the fluid vorticity and
 $r={\it\beta}/{\it\rho}$
where
 ${\it\beta}$
is the Clebsch potential that enforces entropy conservation following the flow. This is a non-local conservation law as it involves the non-local variable
 $r$
. It has the same form as Faraday’s equation in MHD except that
 $\boldsymbol{B}$
is replaced by
 ${\it\bf\Omega}$
. Equation (4.14) gives the fluid helicity conservation law in ideal fluids for cases where
 $\boldsymbol{{\rm\nabla}}S\neq 0$
. This is a non-local conservation law that depends on the non-local variable
 $r$
. The analogous non-local cross helicity conservation law in MHD for cases where
 $\boldsymbol{B}\boldsymbol{\cdot }\boldsymbol{{\rm\nabla}}S\neq 0$
is discussed in (4.15). A further symplecticity conservation law is due to a compatibility condition which requires that time derivative of the the momentum conservation equation minus the gradient of the energy conservation equation is zero. The integrability conditions
 $\text{d}\,\text{d}{\it\omega}^{{\it\alpha}}=0$
on the matrices
 $\unicode[STIX]{x1D612}_{ij}^{\,{\it\alpha}}$
for the MHD system and other multi-symplectic systems were discussed in (4.38). We provided a more consistent treatment of variational principles of the Cartan–Poincaré form for the system, than that given in Webb et al. (Reference Webb, McKenzie and Zank2014c
). We discussed its relation to Cartan’s geometric theory of partial differential equations using differential forms (§§ 4.1 and 4.2). Cendra & Capriotti (Reference Cendra and Capriotti2013) suggest that the formulation of multi-symplectic systems using exterior differential forms is a natural approach in taking into account integrability conditions in the theory.
Acknowledgements
G.M.W. acknowledges discussions with D. Holm and P. Morrison on multi-symplectic MHD. G.M.W. is supported in part by NASA grant NNX15A165G. G.P.Z. was supported in part by NASA grants NN05GG83G and NSF grant nos ATM-03-17509 and ATM-04-28880.



