



1 Introduction
We examine the effect of elasticity on transient axial creeping flow in the annular gap between a rigid cylinder and a concentric elastic tube. The gap between the cylinder and tube is assumed small compared with the radius and length of the cylinder. The flow field is modelled by applying the lubrication approximation, while the external elastic tube is modelled by thin shell theory. We focus on viscous–elastic time scales and nonlinear dynamics, where elastic deformation significantly modifies the boundaries of the fluidic region.
A previous work (Elbaz & Gat Reference Elbaz and Gat2014) examined viscous flow through a slender elastic cylindrical shell, subjected to an external stress field, as a simple model of a soft robot. Under an assumption of small elastic deformations, the analysis yielded a governing inhomogeneous linear diffusion equation and several solutions were examined in the context of soft-robotic applications. Compressibility of the shell material was shown to strongly affect the flow and deformation regimes.
The annular configuration examined in the current work allows for solid deformations to be small compared with the elastic scale but significant in the fluidic domain, thus enabling the use of thin shell theory to study nonlinear viscous–elastic interaction. A similar configuration was examined by Paidoussis (Reference Paidoussis1998) who focused on high Reynolds numbers. The interaction of elastic tubes and thin viscous flows, at the limit of low Reynolds numbers, has been studied by Halpern & Grotberg (Reference Halpern and Grotberg1992) and White & Heil (Reference White and Heil2005) who, among others, analysed the dynamics of a liquid film coating the inner surface of an elastic tube in the context of flows in small airways in the lungs. Other studies involving a thin creeping flow between a rigid surface and an elastic surface focused on planar configurations. These include Chauhan & Radke (Reference Chauhan and Radke2002), who modelled the dynamics of a contact lens during blinking as a thin viscous film contained between an elastic shell and a flat rigid surface. Pihler-Puzović et al. (Reference Pihler-Puzović, Illien, Heil and Juel2012) and Al-Housseiny, Christov & Stone (Reference Al-Housseiny, Christov and Stone2013) studied the effect of elasticity on the onset of Taylor–Saffman fingering instability in Hele-Shaw cells. Pihler-Puzović, Juel & Heil (Reference Pihler-Puzović, Juel and Heil2014) related the patterns of viscous fingering to patterns of wrinkling in an elastic Hele-Shaw cell. Trinh, Wilson & Stone (Reference Trinh, Wilson and Stone2014a ) and Trinh, Wilson & Stone (Reference Trinh, Wilson and Stone2014b ) studied rigid and elastic plates, either pinned or free floating, moving over a viscous film laying on a flat rigid surface. Carlson, Mandre & Mahadevan (Reference Carlson, Mandre and Mahadevan2015) studied the deformation and flow field created by a propagating adhesion front attaching an elastic sheet to a rigid surface, where the gap between the elastic sheet and rigid surface is filled with a viscous fluid.
For the case in which there is initially a small gap between the rigid cylinder and the elastic tube, the examined problem can be viewed as a cylindrical version of the peeling problem (McEwan & Taylor Reference McEwan and Taylor1966; Hosoi & Mahadevan Reference Hosoi and Mahadevan2004; Lister, Peng & Neufeld Reference Lister, Peng and Neufeld2013). In this regard, the peeling formation of the current study bears mathematical proximity to a viscous gravity current (e.g. Buckmaster Reference Buckmaster1977; Huppert Reference Huppert1982; Momoniat Reference Momoniat2006). Gravity currents have also been studied in geophysical contexts when coupled with elastic surfaces (Howell, Robinson & Stone Reference Howell, Robinson and Stone2013; Balmforth, Craster & Hewitt Reference Balmforth, Craster and Hewitt2015; Hewitt, Balmforth & De Bruyn Reference Hewitt, Balmforth and De Bruyn2015).
The suggested configuration may have bearing on models of compliant boundaries (Gad-el Hak Reference Gad-el Hak2002), axisymmetric swimmers (Setter, Bucher & Haber Reference Setter, Bucher and Haber2012; Toppaladoddi & Balmforth Reference Toppaladoddi and Balmforth2014) and soft-robotic applications (Rus & Tolley Reference Rus and Tolley2015). The structure of this work is as follows: in § 2 the geometry, relevant parameters and physical assumptions are defined. In § 3 elastic shell theory and the lubrication approximation are employed to obtain governing equations for the elastohydrodynamic interaction. Section 4 presents closed-form solutions of the governing equations. The interior tensile–viscous regime is described in § 4.1, where we devise propagation laws for different types of boundary conditions and prewetting scales. The dynamics near the propagation front is described in § 4.2, where a uniform matched asymptotic solution connecting the interior region far from the front with a boundary layer region near the front is presented. Section 4.3 examines isolated moving deformations for the case of relative axial speed between the rigid cylinder and the elastic tube. Concluding remarks are presented in § 5.
Schematic illustration of the elastic tube and annular fluid layer enclosing a rigid cylinder. We define the cylindrical coordinates
 $(r,z)$
. Radial and axial solid deformations are denoted
 $d_{r},d_{z}$
, respectively. The radius of the cylinder is
 $r_{b}$
. The dynamic inner and outer surfaces of the elastic tube resulting from the displacement flow are
 $r_{i}+d_{r}(z,t)$
and
 $r_{o}+d_{r}(z,t)$
, respectively. The wall thickness of the tube is denoted by
 $w=r_{o}-r_{i}$
. The penetrating film also causes axial displacement of the tube: a material point
 $z$
shifts to
 $z+d_{z}(z,t)$
. The unperturbed (prewetting) layer is denoted
 $h_{0}$
. The dynamic annular gap, between the cylinder and the elastic tube, is
 $h_{0}+d_{r}(z,t)$
. Inlet pressures denoted
 $p_{0}(t)$
(left) and
 $p_{l}(t)$
(right) are arbitrary functions of time
 $t$
.

2 Problem formulation
We study Newtonian, incompressible, axial creeping flow in the annular gap between a rigid cylinder and a concentric elastic tube, under the limitations of linear elasticity. The cylindrical coordinate system is defined in figure 1 with the axial direction along
 $z$
and radial direction along
 $r$
. A prewetting layer is contained in the gap between the cylinder and the tube and is assumed sufficient so that van der Waals forces can be neglected. Viscous flow due to time-varying inlet pressure as well as relative axial speed between the cylinder and tube will create both radial and axial deformation of the tube. The height of the film contained in the gap, measured radially from the cylinder to the displaced tube, is assumed small compared to the radius and length of the cylinder. We focus on viscous–elastic interaction regimes, where the elastic shell is sufficiently soft that it is deformed significantly by the fluid flow.
Hereafter, normalized variables are denoted by uppercase letters and characteristic parameters are denoted by lowercase letters with asterisks (e.g. if
 $a$
is a dimensional variable,
 $a^{\ast }$
is the characteristic value of
 $a$
and
 $A=a/a^{\ast }$
is the corresponding normalized variable).
The relevant variables and parameters are time
 $t$
, axial coordinate
 $z$
, radial coordinate
 $r$
, axial liquid speed
 $u_{z}$
, radial liquid speed
 $u_{r}$
, liquid pressure
 $p$
, liquid viscosity
 $\unicode[STIX]{x1D707}$
, liquid density
 $\unicode[STIX]{x1D70C}$
, solid axial deformation
 $d_{z}$
, solid radial deformation
 $d_{r}$
, solid strain
 $e_{ij}$
and stress
 $\unicode[STIX]{x1D70E}_{ij}$
(acting on the plane normal to coordinate
 $i$
and in the direction of coordinate
 $j$
), tube inner radius
 $r_{i}$
and outer radius
 $r_{o}$
(see figure 1), tube midsection,
 $r_{m}=(r_{i}+r_{o})/2$
, rigid cylinder radius
 $r_{b}$
and the length
 $l$
of the cylinder and tube in the
 $z$
direction.
The prewetting layer is defined as the gap between the cylinder and inner tube radius,
 $h_{0}=r_{i}-r_{b}$
, when at rest. We define an auxiliary radial coordinate,
 $s=r-r_{b}$
. The slenderness ratio of the cylinder and tube is defined as
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D716}=\frac{r_{b}}{l}. & & \displaystyle\end{eqnarray}$$
The ratio of prewetting thickness to characteristic radial deformation is defined by
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D706}_{h}=\frac{h_{0}}{d_{r}^{\ast }}. & & \displaystyle\end{eqnarray}$$
Small parameters in the analysis include the ratio between the characteristic radial deformation
 $d_{r}^{\ast }$
and the length of the cylinder and tube in the
 $z$
direction,
 $$\begin{eqnarray}\displaystyle \frac{d_{r}^{\ast }}{l}=\unicode[STIX]{x1D700}_{1}\ll 1, & & \displaystyle\end{eqnarray}$$
ratio of wall thickness
 $w=r_{o}-r_{i}$
to inner tube radius
 $r_{i}$
,
 $$\begin{eqnarray}\displaystyle \frac{w}{r_{i}}=\unicode[STIX]{x1D700}_{2}\ll 1 & & \displaystyle\end{eqnarray}$$
and small elastic deformations, expressed by the ratios,
 $$\begin{eqnarray}\displaystyle \frac{d_{r}^{\ast }}{r_{i}}\sim \frac{d_{z}^{\ast }}{l}=\unicode[STIX]{x1D700}_{3}\ll 1, & & \displaystyle\end{eqnarray}$$
where
 $d_{z}^{\ast }$
is the corresponding characteristic axial deformation. We assume negligible inertia,
 $$\begin{eqnarray}\displaystyle \frac{d_{r}^{\ast }}{l}\frac{\unicode[STIX]{x1D70C}u_{z}^{\ast }d_{r}^{\ast }}{\unicode[STIX]{x1D707}}\ll 1, & & \displaystyle\end{eqnarray}$$
where
 $u_{z}^{\ast }$
is characteristic axial liquid velocity (a detailed discussion of the condition of negligible inertia is presented in § 3.3).
3 Analysis
In order to obtain governing equations for the elastohydrodynamic interaction, we apply the lubrication approximation for the flow field and the Kirchhoff–Love thin shell approximation for the solid deformation field, under the requirement of similar time scales of both elastic and fluidic dynamics.
3.1 The elastic problem
The deformation field of axisymmetric linearly elastic material with negligible inertia is governed by the momentum equations,
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}r}(r\unicode[STIX]{x1D70E}_{rr})+\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z}(r\unicode[STIX]{x1D70E}_{zr})-\unicode[STIX]{x1D70E}_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}=0,\quad \frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}r}(r\unicode[STIX]{x1D70E}_{zr})+\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z}(r\unicode[STIX]{x1D70E}_{zz})=0, & & \displaystyle\end{eqnarray}$$
the strain–displacement relations,
 $$\begin{eqnarray}\displaystyle e_{rr}=\frac{\unicode[STIX]{x2202}d_{r}}{\unicode[STIX]{x2202}r},\quad e_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}=\frac{d_{r}}{r},\quad e_{zz}=\frac{\unicode[STIX]{x2202}d_{z}}{\unicode[STIX]{x2202}z},\quad e_{zr}=\frac{1}{2}\left(\frac{\unicode[STIX]{x2202}d_{r}}{\unicode[STIX]{x2202}z}+\frac{\unicode[STIX]{x2202}d_{z}}{\unicode[STIX]{x2202}r}\right), & & \displaystyle\end{eqnarray}$$
and Hooke’s law,
 $$\begin{eqnarray}\displaystyle Ee_{zr}=(1+\unicode[STIX]{x1D708})\unicode[STIX]{x1D70E}_{zr},\quad Ee_{rr}=\unicode[STIX]{x1D70E}_{rr}-\unicode[STIX]{x1D708}(\unicode[STIX]{x1D70E}_{zz}+\unicode[STIX]{x1D70E}_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}),\quad Ee_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}=\unicode[STIX]{x1D70E}_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}-\unicode[STIX]{x1D708}(\unicode[STIX]{x1D70E}_{rr}+\unicode[STIX]{x1D70E}_{zz}),\qquad & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle Ee_{zz}=\unicode[STIX]{x1D70E}_{zz}-\unicode[STIX]{x1D708}(\unicode[STIX]{x1D70E}_{rr}+\unicode[STIX]{x1D70E}_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}), & & \displaystyle\end{eqnarray}$$
where
 $E$
is Young’s modulus and
 $\unicode[STIX]{x1D708}$
is Poisson’s ratio. The boundary conditions for the stress applied by the liquid at
 $r=r_{i}+d_{r}$
are
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D70E}_{rr}(r=r_{i}+d_{r})=-p+2\unicode[STIX]{x1D707}\frac{\unicode[STIX]{x2202}u_{r}}{\unicode[STIX]{x2202}r},\quad \unicode[STIX]{x1D70E}_{zr}(r=r_{i}+d_{r})=\unicode[STIX]{x1D707}\left(\frac{\unicode[STIX]{x2202}u_{z}}{\unicode[STIX]{x2202}r}+\frac{\unicode[STIX]{x2202}u_{r}}{\unicode[STIX]{x2202}z}\right), & & \displaystyle\end{eqnarray}$$
and at
 $r=r_{o}+d_{r}$
the stress vanishes
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D70E}_{rr}(r=r_{o}+d_{r})=0,\quad \unicode[STIX]{x1D70E}_{zr}(r=r_{o}+d_{r})=0. & & \displaystyle\end{eqnarray}$$
We define normalized coordinates,
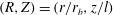 $(R,Z)=(r/r_{b},z/l)$
, normalized radial and axial deflections,
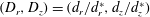 $(D_{r},D_{z})=(d_{r}/d_{r}^{\ast },d_{z}/d_{z}^{\ast })$
and normalized liquid pressure,
 $P=p/p^{\ast }$
, where
 $p^{\ast }$
is the characteristic pressure representing the order of magnitude of the inlet pressure. As we shall see it is related to the characteristic radial deformation by
 $p^{\ast }=d_{r}^{\ast }E\unicode[STIX]{x1D700}_{2}/r_{b}$
. However, the configuration may also be actuated by forced initial deformation of the shell, in which case
 $d_{r}^{\ast }$
should be chosen to represent the characteristic initial deformation and
 $p^{\ast }$
is then obtained by the appropriate relation. Following elastic shell theory (Mollmann Reference Mollmann1981), we define stress resultants for the forces
 $n_{ij}$
and moments
 $m_{ij}$
as
 $$\begin{eqnarray}\displaystyle n_{ij}=\int _{r_{i}}^{r_{o}}\unicode[STIX]{x1D70E}_{ij}\,\text{d}r,\quad m_{ij}=\int _{r_{i}}^{r_{o}}\unicode[STIX]{x1D70E}_{ij}r\,\text{d}r. & & \displaystyle\end{eqnarray}$$
We first integrate the axial momentum equation with respect to
 $r$
, from
 $r_{i}$
to
 $r_{o}$
, to obtain an axial force balance,
 $$\begin{eqnarray}\displaystyle \unicode[STIX]{x1D70E}_{zr}(r_{i})\sim \frac{\unicode[STIX]{x2202}n_{zz}}{\unicode[STIX]{x2202}z}. & & \displaystyle\end{eqnarray}$$
We now multiply the axial momentum equation by
 $r-r_{m}$
and integrate once more over
 $r$
to obtain a resultant form. We then differentiate with respect to
 $z$
in order to relate to the radial momentum equation (3.1). This yields
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}n_{zr}}{\unicode[STIX]{x2202}z}\sim \frac{\unicode[STIX]{x2202}^{2}m_{zz}}{\unicode[STIX]{x2202}z^{2}}+\left(\frac{\unicode[STIX]{x1D700}_{2}r_{m}}{2}-r_{i}\right)\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D70E}_{zr}(r_{i})}{\unicode[STIX]{x2202}z}, & & \displaystyle\end{eqnarray}$$
where we’ve also substituted (3.6).
Substituting into the resultant form of the radial momentum equation,
 $$\begin{eqnarray}\displaystyle n_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}\sim r_{i}p+r_{i}\left(\frac{\unicode[STIX]{x2202}^{2}m_{zz}}{\unicode[STIX]{x2202}z^{2}}+\left(\frac{\unicode[STIX]{x1D700}_{2}r_{m}}{2}-r_{i}\right)\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D70E}_{zr}(r_{i})}{\unicode[STIX]{x2202}z}\right). & & \displaystyle\end{eqnarray}$$
The normal and shear stress scale as
 $\unicode[STIX]{x1D70E}_{rr}\sim p$
and
 $\unicode[STIX]{x1D70E}_{zr}\sim \unicode[STIX]{x1D700}_{1}p$
(this is obtained from the fluidic problem, see § 3.2). Order of magnitude analysis of (3.6) yields the following scaling relations,
 $$\begin{eqnarray}\displaystyle n_{zz}\sim d_{r}p,\quad \unicode[STIX]{x1D70E}_{zz}\sim \frac{p}{\unicode[STIX]{x1D700}_{2}}\unicode[STIX]{x1D700}_{3}, & & \displaystyle\end{eqnarray}$$
and order of magnitude analysis of (3.8) yields
 $$\begin{eqnarray}\displaystyle n_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}\sim r_{b}p,\quad \unicode[STIX]{x1D70E}_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}\sim \frac{p}{\unicode[STIX]{x1D700}_{2}}. & & \displaystyle\end{eqnarray}$$
Taking note that
 $m_{zz}\sim r_{b}n_{zz}$
, normalizing (3.8) yields,
 $$\begin{eqnarray}\displaystyle N_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}\sim P+\unicode[STIX]{x1D700}_{1}\unicode[STIX]{x1D716}\left[\frac{\unicode[STIX]{x2202}^{2}M_{zz}}{\unicode[STIX]{x2202}Z^{2}}+(\unicode[STIX]{x1D700}_{2}-1)\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6F4}_{zr}(1,Z)}{\unicode[STIX]{x2202}Z}\right], & & \displaystyle\end{eqnarray}$$
where we’ve retained the higher derivative of the bending moment
 $M_{zz}$
and the shear stress at the fluid interface
 $\unicode[STIX]{x2202}\unicode[STIX]{x1D6F4}_{zr}(1,Z)/\unicode[STIX]{x2202}Z$
. We normalize Hooke’s law (3.3) according to the above characteristic values and attain a reduced form of Love’s first approximation (Love Reference Love1888),
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D700}_{3}\unicode[STIX]{x1D6F4}_{zz}\sim \frac{\unicode[STIX]{x1D700}_{2}E}{p^{\ast }(1-\unicode[STIX]{x1D708}^{2})}(e_{zz}+\unicode[STIX]{x1D708}e_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}) & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D6F4}_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}\sim \frac{\unicode[STIX]{x1D700}_{2}E}{p^{\ast }(1-\unicode[STIX]{x1D708}^{2})}(e_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}+\unicode[STIX]{x1D708}e_{zz}). & \displaystyle\end{eqnarray}$$
 $\bar{d}_{r}$
and axial
 $\bar{d}_{z}$
displacements of the midsection, denoted by overbars,
 $$\begin{eqnarray}\displaystyle \bar{d}_{z}=d_{z}+(r-r_{m})\frac{\unicode[STIX]{x2202}d_{r}}{\unicode[STIX]{x2202}z},\quad \bar{d}_{r}=d_{r}, & & \displaystyle\end{eqnarray}$$
and thus we can represent the strain as a function of the deformation by
 $$\begin{eqnarray}\displaystyle e_{zz}=\frac{\unicode[STIX]{x2202}\bar{d}_{z}}{\unicode[STIX]{x2202}z}-(r-r_{m})\frac{\unicode[STIX]{x2202}^{2}\bar{d}_{r}}{\unicode[STIX]{x2202}z^{2}},\quad e_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}=\frac{\bar{d}_{r}}{r}. & & \displaystyle\end{eqnarray}$$
Integrating (3.12), (3.13) over
 $r$
into resultant form and evaluating the moment
 $M_{zz}$
, we find that
 $$\begin{eqnarray}\displaystyle & \displaystyle N_{zz}\sim \frac{E\unicode[STIX]{x1D700}_{2}}{p^{\ast }(1-\unicode[STIX]{x1D708}^{2})}\left(\frac{\unicode[STIX]{x2202}\bar{D}_{z}}{\unicode[STIX]{x2202}Z}+\unicode[STIX]{x1D708}\bar{D}_{r}\right), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle N_{\unicode[STIX]{x1D703}\unicode[STIX]{x1D703}}\sim \frac{E\unicode[STIX]{x1D700}_{2}\unicode[STIX]{x1D700}_{3}}{p^{\ast }(1-\unicode[STIX]{x1D708}^{2})}\left(\unicode[STIX]{x1D708}\frac{\unicode[STIX]{x2202}\bar{D}_{z}}{\unicode[STIX]{x2202}Z}+\bar{D}_{r}\right), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle M_{zz}\sim \frac{E\unicode[STIX]{x1D700}_{2}}{p^{\ast }(1-\unicode[STIX]{x1D708}^{2})}\left[\frac{\unicode[STIX]{x2202}\bar{D}_{z}}{\unicode[STIX]{x2202}Z}-\frac{\unicode[STIX]{x1D716}^{2}\unicode[STIX]{x1D700}_{2}^{2}}{12}\frac{\unicode[STIX]{x2202}^{2}\bar{D}_{r}}{\unicode[STIX]{x2202}Z^{2}}+\unicode[STIX]{x1D708}\bar{D}_{r}\right], & & \displaystyle\end{eqnarray}$$
where
 $\bar{D}_{r},\bar{D}_{z}$
are the non-dimensional displacements of the midsection. The term
 $\unicode[STIX]{x2202}\bar{D}_{z}/\unicode[STIX]{x2202}Z$
can be evaluated between (3.6) and (3.16). We can now express (3.11) in terms of fluid pressure and radial deformation,
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x1D716}^{4}\unicode[STIX]{x1D700}_{2}^{2}}{12(1-\unicode[STIX]{x1D708}^{2})}\frac{\unicode[STIX]{x2202}^{4}\bar{D}_{r}}{\unicode[STIX]{x2202}Z^{4}}-\frac{\unicode[STIX]{x1D716}\unicode[STIX]{x1D700}_{1}\unicode[STIX]{x1D700}_{2}}{2}\frac{\unicode[STIX]{x2202}\unicode[STIX]{x1D6F4}_{zr}(1,Z)}{\unicode[STIX]{x2202}Z}+\bar{D}_{r}\sim P. & & \displaystyle\end{eqnarray}$$
The leading order of (3.19) is a tensile regime in which
 $\bar{D}_{r}\sim P$
. However, the small term
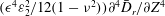 $(\unicode[STIX]{x1D716}^{4}\unicode[STIX]{x1D700}_{2}^{2}/12(1-\unicode[STIX]{x1D708}^{2}))\unicode[STIX]{x2202}^{4}\bar{D}_{r}/\unicode[STIX]{x2202}Z^{4}$
may become dominant in a boundary layer near the location of a fixed end of the tube or near a peeling front, as the fluid layer thickness goes to zero at the edge of a penetrating film. The small term
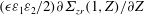 $(\unicode[STIX]{x1D716}\unicode[STIX]{x1D700}_{1}\unicode[STIX]{x1D700}_{2}/2)\unicode[STIX]{x2202}\unicode[STIX]{x1D6F4}_{zr}(1,Z)/\unicode[STIX]{x2202}Z$
, as we shall see, increases inversely with the fluid layer thickness near the peeling front and thus will undergo rescaling in the contact line analysis (see § 4.2).
The corresponding relation between radial and axial deformations reads
 $$\begin{eqnarray}\displaystyle \bar{D}_{z}(Z,T)-\bar{D}_{z}(Z=0,T)\sim -\unicode[STIX]{x1D708}\int _{0}^{Z}\bar{D}_{r}(\unicode[STIX]{x1D701},T)\,\text{d}\unicode[STIX]{x1D701}, & & \displaystyle\end{eqnarray}$$
which simply describes the stretching of the tube as it expands; a result of Poisson’s effect. We conclude the elastic analysis with the relation between the characteristic radial deformation and characteristic pressure, representing the dominant elastic tension to viscous force balance,
 $$\begin{eqnarray}\displaystyle \frac{p^{\ast }}{E\unicode[STIX]{x1D700}_{2}}=\frac{d_{r}^{\ast }}{r_{b}}=\unicode[STIX]{x1D700}_{3}\ll 1. & & \displaystyle\end{eqnarray}$$
Equation (3.21) provides limitation on the maximal allowed pressure for which the assumption of small deformations is valid. Hereafter the midsection overbars are omitted for simplicity.
3.2 The fluidic problem
We assume an axisymmetric incompressible Newtonian flow, governed by the momentum equations,
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D70C}\left(\frac{\unicode[STIX]{x2202}u_{r}}{\unicode[STIX]{x2202}t}+u_{r}\frac{\unicode[STIX]{x2202}u_{r}}{\unicode[STIX]{x2202}r}+u_{z}\frac{\unicode[STIX]{x2202}u_{r}}{\unicode[STIX]{x2202}z}\right)=-\frac{\unicode[STIX]{x2202}p}{\unicode[STIX]{x2202}r}+\unicode[STIX]{x1D707}\left[\frac{1}{r}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}r}\left(r\frac{\unicode[STIX]{x2202}u_{r}}{\unicode[STIX]{x2202}r}\right)+\frac{\unicode[STIX]{x2202}^{2}u_{r}}{\unicode[STIX]{x2202}z^{2}}-\frac{u_{r}}{r^{2}}\right], & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \unicode[STIX]{x1D70C}\left(\frac{\unicode[STIX]{x2202}u_{z}}{\unicode[STIX]{x2202}t}+u_{r}\frac{\unicode[STIX]{x2202}u_{z}}{\unicode[STIX]{x2202}r}+u_{z}\frac{\unicode[STIX]{x2202}u_{z}}{\unicode[STIX]{x2202}z}\right)=-\frac{\unicode[STIX]{x2202}p}{\unicode[STIX]{x2202}z}+\unicode[STIX]{x1D707}\left[\frac{1}{r}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}r}\left(r\frac{\unicode[STIX]{x2202}u_{z}}{\unicode[STIX]{x2202}r}\right)+\frac{\unicode[STIX]{x2202}^{2}u_{z}}{\unicode[STIX]{x2202}z^{2}}\right]+\unicode[STIX]{x1D70C}g, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \frac{1}{r}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}r}(ru_{r})+\frac{\unicode[STIX]{x2202}u_{z}}{\unicode[STIX]{x2202}z}=0. & & \displaystyle\end{eqnarray}$$
The relevant boundary conditions are no slip and no penetration at
 $r=r_{i}+d_{r}$
,
 $$\begin{eqnarray}\displaystyle u_{r}(r=r_{b}+h_{0}+d_{r})=\frac{\unicode[STIX]{x2202}d_{r}}{\unicode[STIX]{x2202}t},\quad u_{z}(r=r_{b}+h_{0}+d_{r})=\frac{\unicode[STIX]{x2202}d_{z}}{\unicode[STIX]{x2202}t}, & & \displaystyle\end{eqnarray}$$
and at the rigid cylinder boundary,
 $r=r_{b}$
,
 $$\begin{eqnarray}\displaystyle u_{r}(r=r_{b})=0,\quad u_{z}(r=r_{b})=u_{0}. & & \displaystyle\end{eqnarray}$$
Pressure at the inlet and outlet may be governed by
 $$\begin{eqnarray}\displaystyle p(z=0)=p_{0}(t),\quad p(z=l)=p_{l}(t), & & \displaystyle\end{eqnarray}$$
where
 $p_{0}(t)$
and
 $p_{l}(t)$
are arbitrary functions of time having order of magnitude
 $p^{\ast }$
. We define normalized liquid velocities
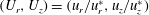 $(U_{r},U_{z})=(u_{r}/u_{r}^{\ast },u_{z}/u_{z}^{\ast })$
, and normalize the coordinate
 $s=r-r_{b}$
, defined in the gap
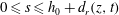 $0\leqslant s\leqslant h_{0}+d_{r}(z,t)$
, by
 $d_{r}^{\ast }$
,
 $$\begin{eqnarray}\displaystyle S=\frac{s}{d_{r}^{\ast }},\quad 0\leqslant S\leqslant \unicode[STIX]{x1D706}_{h}+D_{r}(Z,T). & & \displaystyle\end{eqnarray}$$
Order of magnitude analysis of (3.24) yields
 $$\begin{eqnarray}\displaystyle \frac{u_{r}^{\ast }}{u_{z}^{\ast }}\sim \frac{d_{r}^{\ast }}{l}=\unicode[STIX]{x1D700}_{1},\quad u_{z}^{\ast }=\frac{\unicode[STIX]{x1D700}_{1}d_{r}^{\ast }p^{\ast }}{\unicode[STIX]{x1D707}}. & & \displaystyle\end{eqnarray}$$
We require
 $u_{0}\sim u_{z}^{\ast }$
so that the viscous stresses resulting from the motion of the rigid cylinder scale as
 $\unicode[STIX]{x1D707}u_{0}/d_{r}^{\ast }$
. We focus on negligible gravity,
 $G=\unicode[STIX]{x1D70C}gl/p^{\ast }\ll 1$
, and define the Reynolds number,
 $Re=\unicode[STIX]{x1D70C}u_{z}^{\ast }d_{r}^{\ast }/\unicode[STIX]{x1D707}$
and the Womersley number,
 $W^{2}=\unicode[STIX]{x1D70C}d_{r}^{\ast 2}/\unicode[STIX]{x1D707}t^{\ast }$
. We transform (3.22)–(3.24) from
 $R\rightarrow S$
and employ (3.29). The result is the following reduced system for the fluidic domain,
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}P}{\unicode[STIX]{x2202}Z}=\frac{\unicode[STIX]{x2202}^{2}U_{z}}{\unicode[STIX]{x2202}S^{2}}+O(W^{2},\unicode[STIX]{x1D700}_{3},\unicode[STIX]{x1D700}_{1}Re,\unicode[STIX]{x1D700}_{1}^{2},G), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}P}{\unicode[STIX]{x2202}S}=O(W^{2},\unicode[STIX]{x1D700}_{1}^{3}Re,\unicode[STIX]{x1D700}_{1}^{2}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}U_{r}}{\unicode[STIX]{x2202}S}+\frac{\unicode[STIX]{x2202}U_{z}}{\unicode[STIX]{x2202}Z}=O(\unicode[STIX]{x1D700}_{3}). & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle U_{r}(S=\unicode[STIX]{x1D706}_{h}+D_{r})=\frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}T},\quad U_{z}(S=\unicode[STIX]{x1D706}_{h}+D_{r})=\frac{d_{z}^{\ast }}{t^{\ast }u_{z}^{\ast }}\frac{\unicode[STIX]{x2202}D_{z}}{\unicode[STIX]{x2202}T}, & & \displaystyle\end{eqnarray}$$
and
 $$\begin{eqnarray}\displaystyle U_{r}(S=0)=0,\quad U_{z}(S=0)=U_{0}, & & \displaystyle\end{eqnarray}$$
with
 $U_{0}=u_{0}/u_{z}^{\ast }$
and
 $T=t/t^{\ast }$
, where
 $t^{\ast }\sim d_{r}^{\ast }/u_{r}^{\ast }$
is the time scale of the viscous–elastic interaction to be defined shortly (see (3.35)). We solve (3.30a
), (3.30b
) imposing conditions (3.31). The resulting leading-order axial speed
 $U_{z}$
reads
 $$\begin{eqnarray}\displaystyle U_{z}\sim \frac{1}{2}\frac{\unicode[STIX]{x2202}P}{\unicode[STIX]{x2202}Z}[S^{2}-\left(\unicode[STIX]{x1D706}_{h}+D_{r}\right)S]+\frac{S}{(\unicode[STIX]{x1D706}_{h}+D_{r})}\frac{d_{z}^{\ast }}{t^{\ast }u_{z}^{\ast }}\frac{\unicode[STIX]{x2202}D_{z}}{\unicode[STIX]{x2202}T}+U_{0}\left[1-\frac{S}{(\unicode[STIX]{x1D706}_{h}+D_{r})}\right], & & \displaystyle\end{eqnarray}$$
and is defined for
 $\unicode[STIX]{x1D706}_{h}+D_{r}\geqslant 0$
. Addressing mass conservation (3.30c
), we install (3.32) and integrate with respect to
 $S$
across the film layer to produce a reduced Reynolds equation relating fluidic pressure to elastic deformations,
 $$\begin{eqnarray}\displaystyle & & \displaystyle \frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}T}-4\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}Z}\left\{\frac{\unicode[STIX]{x2202}P}{\unicode[STIX]{x2202}Z}(\unicode[STIX]{x1D706}_{h}+D_{r})^{3}\right\}+24U_{0}\frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}Z}\nonumber\\ \displaystyle & & \displaystyle \sim \frac{\unicode[STIX]{x1D700}_{3}}{2}\left[\frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}Z}\frac{\unicode[STIX]{x2202}D_{z}}{\unicode[STIX]{x2202}T}-(\unicode[STIX]{x1D706}_{h}+D_{r})\frac{\unicode[STIX]{x2202}^{2}D_{z}}{\unicode[STIX]{x2202}Z\unicode[STIX]{x2202}T}\right].\end{eqnarray}$$
Equation (3.33) is valid for
 $\unicode[STIX]{x1D706}_{h}+D_{r}\geqslant 0$
. The residual axial speed correction terms (of order
 $O(\unicode[STIX]{x1D700}_{3})$
) have been included for reference.
3.3 The fluidic–elastic problem
Equations (3.19) and (3.33) yield a coupled set in pressure and deformation which governs the elastohydrodynamic interaction (for the corresponding dimensional equations see (A 1)),
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x1D716}^{4}\unicode[STIX]{x1D700}_{2}^{2}}{12(1-\unicode[STIX]{x1D708}^{2})}\frac{\unicode[STIX]{x2202}^{4}D_{r}}{\unicode[STIX]{x2202}Z^{4}}-\frac{\unicode[STIX]{x1D716}\unicode[STIX]{x1D700}_{1}\unicode[STIX]{x1D700}_{2}}{2}\left[\frac{(\unicode[STIX]{x1D706}_{h}+D_{r})}{2}\frac{\unicode[STIX]{x2202}^{2}P}{\unicode[STIX]{x2202}Z^{2}}+\left(\frac{U_{0}}{(\unicode[STIX]{x1D706}_{h}+D_{r})^{2}}-\frac{1}{2}\frac{\unicode[STIX]{x2202}P}{\unicode[STIX]{x2202}Z}\right)\frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}Z}\right]+D_{r}\sim P, & \displaystyle \nonumber\\ \displaystyle & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}T}\sim 4\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}Z}\left\{\frac{\unicode[STIX]{x2202}P}{\unicode[STIX]{x2202}Z}(\unicode[STIX]{x1D706}_{h}+D_{r})^{3}\right\}-24U_{0}\frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}Z}. & \displaystyle\end{eqnarray}$$
 $t^{\ast }$
is evaluated via relations (3.21) and (3.29) (an extra factor of
 $48$
is included for convenience),
 $$\begin{eqnarray}\displaystyle t^{\ast }=\frac{48(E\unicode[STIX]{x1D700}_{2})^{2}\unicode[STIX]{x1D707}}{{p^{\ast }}^{3}\unicode[STIX]{x1D716}^{2}}=\frac{48(Ew)^{2}l^{2}\unicode[STIX]{x1D707}}{{p^{\ast }}^{3}r_{b}^{4}}, & & \displaystyle\end{eqnarray}$$
and is written in terms of the characteristic driving pressure. This dependence stems from the nonlinearity of (3.34b
). Equation (3.35) enables us to estimate an upper limit on the characteristic pressure beyond which the assumption of negligible inertia (3.30a
)–(3.30b
) will no longer be valid, representing the range of validity of the analysis. Substituting (3.35) into (3.30a
), we demand that both
 $W^{2}$
and
 $\unicode[STIX]{x1D700}_{1}Re$
terms be negligible and derive the condition that
 $$\begin{eqnarray}\displaystyle p^{\ast }\ll \left(\frac{\unicode[STIX]{x1D707}}{\unicode[STIX]{x1D716}r_{b}}\right)^{2/5}\frac{(E\unicode[STIX]{x1D700}_{2})^{4/5}}{\unicode[STIX]{x1D70C}^{1/5}}=\frac{(\unicode[STIX]{x1D707}l)^{2/5}(Ew)^{4/5}}{r_{b}^{8/5}\unicode[STIX]{x1D70C}^{1/5}}. & & \displaystyle\end{eqnarray}$$
We note that for the case of small deformations compared with the prewetting thickness (
 $d_{r}\ll h_{0}$
), bending and shear stresses can be neglected, and hence (3.34a
) reduces to
 $D_{r}\sim P$
. Substituting back into (3.34b
) and setting
 $D_{r}\ll \unicode[STIX]{x1D706}_{h}$
in the diffusion coefficient yields the linearized form
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}T}\sim 4\frac{\unicode[STIX]{x2202}^{2}D_{r}}{\unicode[STIX]{x2202}Z^{2}}, & & \displaystyle\end{eqnarray}$$
where the transport effect of the rigid cylinder motion vanishes at the presence of a thick intermediate layer. For the linear case, the appropriate time scale instead of
 $t^{\ast }$
is
 $r_{b}^{2}l^{2}\unicode[STIX]{x1D707}/Ewh_{0}^{3}$
and shows exclusive dependence in solid–liquid material properties and the geometry of the configuration. A result which is consistent with the linear interaction time scale of the full cross-section cylindrical shell (Elbaz & Gat Reference Elbaz and Gat2014).
4 Results
4.1 The tensile–viscous regime
In the following analysis we shall assume that the viscous dissipation near the apparent contact line is negligible compared with the viscous dissipation in the bulk of the fluid. Consequently, we shall first seek a solution in the form of an interior profile, balancing elastic tension and viscous forces in (3.34) under an assumption of a small, lower bounded,
 $\unicode[STIX]{x1D706}_{h}$
. In § 4.2 we rescale the governing equations and examine the behaviour near the contact line, assuming conditions in the interior remain unchanged. We in turn discuss several lower bounds on
 $\unicode[STIX]{x1D706}_{h}$
which emanate from the analysis at the front.
4.1.1 Deformation significantly larger than prewetting
For axial length scales of
 $Z=O(1)$
bending and shear stresses can be neglected and hence (3.34a
) reduces to
 $D_{r}\sim P$
. At the limit of large defection compared with prewetting,
 $\unicode[STIX]{x1D706}_{h}\ll 1$
(for stationary rigid cylinder
 $U_{0}=0$
), (3.34b
) then reduces to the well-known porous medium equation (PME) in fourth power,
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}T}\sim \frac{\unicode[STIX]{x2202}^{2}D_{r}^{4}}{\unicode[STIX]{x2202}Z^{2}}. & & \displaystyle\end{eqnarray}$$
We transform to self-similar variables,
 $$\begin{eqnarray}\displaystyle D_{r}=T^{-\unicode[STIX]{x1D6FC}}f(\unicode[STIX]{x1D702}),\quad \unicode[STIX]{x1D702}=ZT^{(3\unicode[STIX]{x1D6FC}-1)/2}, & & \displaystyle\end{eqnarray}$$
and follow Huppert (Reference Huppert1982) in light of the close analogy to a viscous gravity current propagating under a density gradient.
 $$\begin{eqnarray}\displaystyle F(\unicode[STIX]{x1D709})=\unicode[STIX]{x1D702}_{_{F}}^{-2/3}f(\unicode[STIX]{x1D702}),\quad \unicode[STIX]{x1D702}=\unicode[STIX]{x1D702}_{_{F}}\unicode[STIX]{x1D709}. & & \displaystyle\end{eqnarray}$$
Here
 $\unicode[STIX]{x1D702}_{_{F}}$
describes a propagating peeling front for which the solution is supported in the region
 $Z<Z_{_{F}}(T)$
, prior to boundary interaction
 $Z_{_{F}}(T)<1$
. We install (4.2), (4.3) into (4.1) which then reduces to the following ordinary differential equation (ODE) in
 $F$
,
 $$\begin{eqnarray}\displaystyle F^{4\prime \prime }\sim \left(\frac{3\unicode[STIX]{x1D6FC}-1}{2}\right)\unicode[STIX]{x1D709}F^{\prime }-\unicode[STIX]{x1D6FC}F. & & \displaystyle\end{eqnarray}$$
The eigenvalue
 $\unicode[STIX]{x1D6FC}$
describes the height of the film at the inlet,
 $$\begin{eqnarray}\displaystyle D_{r}(0,T)=T^{-\unicode[STIX]{x1D6FC}}, & & \displaystyle\end{eqnarray}$$
which equivalently represents inlet pressure in this regime. Boundary conditions are restated in
 $F$
,
 $$\begin{eqnarray}\displaystyle F(0)=\unicode[STIX]{x1D702}_{_{F}}^{-2/3},\quad F(\unicode[STIX]{x1D709}\geqslant 1)=0. & & \displaystyle\end{eqnarray}$$
We complete the formulation with integral mass conservation represented in non-dimensional form by
 $$\begin{eqnarray}\displaystyle \int _{0}^{Z_{_{F}}(T)}D_{r}(Z,T)\,\text{d}Z=QT^{(1-5\unicode[STIX]{x1D6FC})/2},\quad Q=\unicode[STIX]{x1D702}_{_{F}}^{5/3}\int _{0}^{1}F(\unicode[STIX]{x1D709})\,\text{d}\unicode[STIX]{x1D709}. & & \displaystyle\end{eqnarray}$$
Both
 $\unicode[STIX]{x1D702}_{_{F}}$
and
 $Q$
are functions of the eigenvalue
 $\unicode[STIX]{x1D6FC}$
. Contrary to a viscous gravity current where the interface is induced by a given flux input, in which case the flux rate
 $Q$
may be set constant for all
 $\unicode[STIX]{x1D6FC}$
, in the current study the flux rate derives from the inlet conditions.
We first consider the specific case
 $\unicode[STIX]{x1D6FC}=1/5$
for which equation (4.4) may be solved analytically. The solution is a particular case of the source solution of the PME, known as the ZKB solution as it was first obtained by Zel’dovich & Kompaneets (Reference Zel’dovich and Kompaneets1950) and Barenblatt (Reference Barenblatt1952). The underlying boundary and initial conditions are
 $$\begin{eqnarray}\displaystyle D_{r}(Z,0)=Q\unicode[STIX]{x1D6FF}(Z),\quad \frac{\unicode[STIX]{x2202}D_{r}(0,T)}{\unicode[STIX]{x2202}Z}=0, & & \displaystyle\end{eqnarray}$$
representing a sudden input of mass,
 $Q$
, into the interface at
 $T=0$
, after which the inlet is sealed. The amplitude decay at the inlet, as the front spreads through the interface, is then given by (4.5). The solution reads
 $$\begin{eqnarray}\displaystyle D_{r}(Z,T)=T^{-1/5}\left[1-\frac{3}{40}Z^{2}T^{-2/5}\right]_{+}^{1/3},\quad Q=\frac{\sqrt{\displaystyle \frac{10\unicode[STIX]{x03C0}}{3}}\unicode[STIX]{x1D6E4}\left(\displaystyle \frac{4}{3}\right)}{\unicode[STIX]{x1D6E4}\left(\displaystyle \frac{11}{6}\right)},\quad \unicode[STIX]{x1D702}_{_{F}}=\sqrt{\frac{40}{3}},\quad \qquad & & \displaystyle\end{eqnarray}$$
where
 $(s)_{_{+}}=\max (s,0)$
and
 $\unicode[STIX]{x1D6E4}$
is Euler’s gamma function. The velocity field corresponding to (4.9) can be attained via (3.32) and (3.30c
). The dimensional solution corresponding to (4.9) is given by (A 2). For all other physical values of
 $\unicode[STIX]{x1D6FC}$
(
 $\unicode[STIX]{x1D6FC}<1/5$
) (4.4), along with conditions (4.6) and (4.7), must be solved numerically. In the range
 $\unicode[STIX]{x1D6FC}\leqslant 0$
the underlying initial condition is
 $D_{r}(Z,0)=0$
. Figure 2(a) presents the self-similar displacement profiles
 $F(\unicode[STIX]{x1D709})$
, analogous to a two-dimensional viscous gravity current. Figure 2(b) depicts the flux rate
 $Q$
, the front locus
 $\unicode[STIX]{x1D702}_{_{F}}$
and the time it takes the front to reach the opposite boundary, denoted
 $T_{b}$
, as a function of
 $\unicode[STIX]{x1D6FC}$
. The time
 $T_{b}$
represents the limit of validity of the self-similar analysis when adapted to a finite domain. Figure 2(c,d) depict the resulting deformation regime,
 $D_{z}$
and
 $D_{r}$
, respectively, for the case of constant inlet height (
 $\unicode[STIX]{x1D6FC}=0$
). The peeling front enters from the left (
 $Z=0$
) while the tube is set stationary at the right end
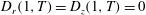 $D_{r}(1,T)=D_{z}(1,T)=0$
. The axial deformation is attained via (3.20). As the front propagates the interface, the free left end of the tube retracts towards the right; during this process we assume the inlet remains sealed.
Self-similar solutions of the tensile–viscous regime, corresponding to
 $\unicode[STIX]{x1D706}_{h}\ll 1$
,
 $U_{0}=0$
and inlet conditions
 $D_{r}(0,T)=T^{-\unicode[STIX]{x1D6FC}}$
. (a) Displacement profile
 $F(\unicode[STIX]{x1D709})$
corresponding to eigenvalues:
 $\unicode[STIX]{x1D6FC}=1/5$
(analytic – solution (4.9)) – dashed line,
 $\unicode[STIX]{x1D6FC}=0$
,
 $-1,-2,-3$
– solid lines (obtained numerically). (b) Flux rate
 $Q(\unicode[STIX]{x1D6FC})$
– solid line, front locus
 $\unicode[STIX]{x1D702}_{_{F}}(\unicode[STIX]{x1D6FC})$
– dashed-dotted line, time to boundary
 $T_{b}(\unicode[STIX]{x1D6FC})=t_{b}/t^{\ast }$
– dashed line (
 $Q,\unicode[STIX]{x1D702}_{_{F}}$
and
 $T_{b}$
obtained numerically). Panel (b) is plotted in the range
 $\unicode[STIX]{x1D6FC}\leqslant 0$
(the range
 $0<\unicode[STIX]{x1D6FC}\leqslant 1/5$
is irrelevant for comparison due to the change in boundary and initial conditions). (c,d) Constant-inlet-height (
 $\unicode[STIX]{x1D6FC}=0$
) propagation in time with
 $\unicode[STIX]{x0394}T=1/30$
, between
 $0\leqslant T\leqslant 1/3$
, tube clamped at
 $Z=1$
,
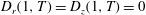 $D_{r}(1,T)=D_{z}(1,T)=0$
. (c) Axial deformation
 $D_{z}(Z,T)/\unicode[STIX]{x1D708}$
. (d) Radial deformation
 $D_{r}(Z,T)$
.

The propagation laws for an inlet signal of type (4.5), according to self-similarity, are written in terms of the front location
 $Z_{_{F}}$
, accumulated mass in the interface
 $M$
and time to boundary
 $T_{b}$
,
 $$\begin{eqnarray}\displaystyle Z_{_{F}}=\unicode[STIX]{x1D702}_{_{F}}(\unicode[STIX]{x1D6FC})T^{(1-3\unicode[STIX]{x1D6FC})/2},\quad M=Q(\unicode[STIX]{x1D6FC})T^{(1-5\unicode[STIX]{x1D6FC})/2},\quad T_{b}={\unicode[STIX]{x1D702}_{_{F}}(\unicode[STIX]{x1D6FC})}^{-2/(1-3\unicode[STIX]{x1D6FC})}. & & \displaystyle\end{eqnarray}$$
The corresponding dimensional propagation laws are given in (A 3). Relations (4.10) illustrate the dependence of the spread rate in the inlet conditions for large displacements compared with the prewetting thickness
 $d_{r}\gg h_{0}$
. This is not the case for small displacements
 $d_{r}\ll h_{0}$
, governed by (3.37), for which the spread rate
 $O(t^{1/2})$
(heat equation) is constant for all inlet conditions.
4.1.2 Deformation comparable to prewetting
When the deformation is of similar magnitude as the prewetting layer, we cannot neglect
 $\unicode[STIX]{x1D706}_{h}$
as in (4.1), but must consider the more general case,
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}T}\sim 4\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}Z}\left\{\frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}Z}(\unicode[STIX]{x1D706}_{h}+D_{r})^{3}\right\}. & & \displaystyle\end{eqnarray}$$
We note that propagation over a non-negligible prewetting layer in the current configuration is analogous to the propagation of a viscous gravity current at a fluid interface (Lister & Kerr Reference Lister and Kerr1989). We transform back to PME form in film height
 $H=\unicode[STIX]{x1D706}_{h}+D_{r}$
,
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}H}{\unicode[STIX]{x2202}T}\sim \frac{\unicode[STIX]{x2202}^{2}H^{4}}{\unicode[STIX]{x2202}Z^{2}}, & & \displaystyle\end{eqnarray}$$
and note that similarity solutions exist only for the case where there is a fixed height scale in addition to the prewetting thickness. We thus consider the case of constant-inlet-height propagation, analogous to
 $\unicode[STIX]{x1D6FC}=0$
in (4.5) but for general
 $\unicode[STIX]{x1D706}_{h}$
,
 $$\begin{eqnarray}\displaystyle H(0,T)=1+\unicode[STIX]{x1D706}_{h},\quad H(Z,0)=\unicode[STIX]{x1D706}_{h}. & & \displaystyle\end{eqnarray}$$
We substitute
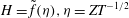 $H=\tilde{f}(\unicode[STIX]{x1D702}),\unicode[STIX]{x1D702}=ZT^{-1/2}$
and derive the following boundary value problem in
 $\tilde{f}$
(analogous to (4.4)–(4.7)),
 $$\begin{eqnarray}\displaystyle \tilde{f}^{4\prime \prime }\sim -{\textstyle \frac{1}{2}}\unicode[STIX]{x1D702}\tilde{f}^{\prime }, & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \tilde{f}(0)=1+\unicode[STIX]{x1D706}_{h},\quad \tilde{f}(\infty )=\unicode[STIX]{x1D706}_{h}, & & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle \int _{0}^{\infty }D_{r}(Z,T)\,\text{d}Z=\widetilde{Q}T^{1/2},\quad \widetilde{Q}=\int _{0}^{\infty }[\tilde{f}(\unicode[STIX]{x1D702})-\unicode[STIX]{x1D706}_{h}]\,\text{d}\unicode[STIX]{x1D702}. & & \displaystyle\end{eqnarray}$$
We have used the tilde symbol to denote
 $\unicode[STIX]{x1D706}_{h}$
dependency. The numerical solution of (4.14) is presented in figure 3(a) and starts from the inner profile of
 $D_{r}(\unicode[STIX]{x1D702})$
previously attained for
 $\unicode[STIX]{x1D706}_{h}\ll 1$
. Subsequent profiles correspond to
 $0.1\leqslant \unicode[STIX]{x1D706}_{h}\leqslant 1$
in
 $0.1$
increments. The resulting axial deformation profile
 $D_{z}(\unicode[STIX]{x1D702})/\unicode[STIX]{x1D708}$
for
 $T=1$
, in the case where the tube is clamped ahead of any displacement, is plotted in figure 3(b); its intersection with the axis
 $\unicode[STIX]{x1D702}=0$
yields the flux rate,
 $\widetilde{Q}(\unicode[STIX]{x1D706}_{h})$
.
Self-similar solutions of the tensile–viscous regime for non-negligible prewetting, corresponding to
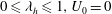 $0\leqslant \unicode[STIX]{x1D706}_{h}\leqslant 1,U_{0}=0$
and constant inlet displacement/pressure
 $D_{r}(0,T)=1$
. (a) Radial deformation profile
 $D_{r}(\unicode[STIX]{x1D702})$
in
 $\unicode[STIX]{x0394}\unicode[STIX]{x1D706}_{h}=0.1$
increments (obtained numerically)
 $0\leqslant \unicode[STIX]{x1D706}_{h}\leqslant 0.5$
– solid lines,
 $0.6\leqslant \unicode[STIX]{x1D706}_{h}\leqslant 1$
– dashed lines. (b) Axial deformation profile
 $D_{z}(\unicode[STIX]{x1D702})/\unicode[STIX]{x1D708}$
at
 $T=1$
in
 $\unicode[STIX]{x0394}\unicode[STIX]{x1D706}_{h}=0.1$
increments; yields the flux rate
 $\widetilde{Q}(\unicode[STIX]{x1D706}_{h})$
at
 $\unicode[STIX]{x1D702}=0$
(tube clamped ahead of any displacement:
 $D_{z}=0$
at
 $\unicode[STIX]{x1D702}\rightarrow \infty$
).

For non-negligible
 $\unicode[STIX]{x1D706}_{h}$
(4.11) is no longer parabolic degenerate for
 $D_{r}=0$
, causing the edge to trail to infinity. The fluid displacement travels as
 $O(T^{1/2})$
but is no longer compactly supported. The accumulated mass in the interface excluding the base layer is given by
 $\widetilde{M}=\widetilde{Q}(\unicode[STIX]{x1D706}_{h})T^{1/2}$
. We would like to emphasize that this unified self-similar law of
 $O(t^{1/2})$
for all prewetting thicknesses is a unique property of fixed-inlet-height propagation. Note, for example, that source-type boundary conditions transition from
 $O(t^{1/5})$
propagation for
 $\unicode[STIX]{x1D706}_{h}\ll 1$
(solution (4.9)) to
 $O(t^{1/2})$
for
 $\unicode[STIX]{x1D706}_{h}\rightarrow \infty$
(solution of (3.37)). For intermediate values of
 $\unicode[STIX]{x1D706}_{h}$
a numerical solution is required and is illustrated below. We solve (4.11) along with appropriate boundary conditions,
 $$\begin{eqnarray}\displaystyle D_{r}(Z,0)=\unicode[STIX]{x1D6FF}(Z),\quad \frac{\unicode[STIX]{x2202}D_{r}(0,T)}{\unicode[STIX]{x2202}Z}=\frac{\unicode[STIX]{x2202}D_{r}(1,T)}{\unicode[STIX]{x2202}Z}=0. & & \displaystyle\end{eqnarray}$$
A no-flux condition at the right boundary has been added to demonstrate the interaction of the front with the opposing wall. Propagation in time is shown in 3 snapshots in figure 4(a,b,c) corresponding to
 $T=0.012,0.12,0.6$
, respectively, and for varying base layer thickness
 $0\leqslant \unicode[STIX]{x1D706}_{h}\leqslant 3/2$
. The solution was obtained via a finite difference scheme and was validated on the basis of (4.9). A faster advancement of the front as well as its spreading are observed for thicker base layers. For
 $\unicode[STIX]{x1D706}_{h}>1$
the solution is presented in the nonlinear time scale normalization (3.35) for comparison and converges rapidly to the behaviour of (3.37).
Source-type propagation over a prewetting layer in the tensile–viscous regime. Numerical solution corresponding to
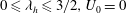 $0\leqslant \unicode[STIX]{x1D706}_{h}\leqslant 3/2,U_{0}=0$
,
 $0\leqslant T\leqslant 1/80$
. Radial deformation plotted versus axial coordinate. Boundary conditions of type (4.15).
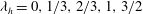 $\unicode[STIX]{x1D706}_{h}=0,1/3,2/3,1,3/2$
from dark to light reds respectively. (a) Solution at time
 $T=1/4000$
, (b) solution at time
 $T=1/400$
, (c) solution at time
 $T=1/80$
.

4.2 The elastohydrodynamic front
While solution (4.9) describes a moving contact line, it neglects higher-order terms which may be dominant in its vicinity. In the following analysis we examine the viscous–elastic dynamics near the propagation front. We assume a small, lower bounded, prewetting layer
 $\unicode[STIX]{x1D706}_{h}\ll 1$
and a shortening of the axial length scale to
 $Z=O(\unicode[STIX]{x1D6FF})$
near the contact line. We transform (3.34) (
 $U_{0}=0$
) to the self-similar variable
 $\unicode[STIX]{x1D709}=Z/Z_{_{F}}$
, and rescale to the boundary layer coordinate
 $\unicode[STIX]{x1D709}=1-\unicode[STIX]{x1D701}\unicode[STIX]{x1D6FF}$
. Equations (3.34) can be uncoupled and the result is the following ODE in the boundary layer variable
 $\hat{D}_{r}(\unicode[STIX]{x1D701})$
, written prior to balance,
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x1D716}^{4}\unicode[STIX]{x1D700}_{2}^{2}}{12(1-\unicode[STIX]{x1D708}^{2})Z_{F}^{4}}\frac{1}{\unicode[STIX]{x1D6FF}^{4}}\frac{\unicode[STIX]{x2202}^{4}\hat{D}_{r}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D701}^{4}}+\hat{D}_{r}\sim \unicode[STIX]{x1D6FF}\int _{0}^{\unicode[STIX]{x1D701}}\frac{Z_{F}{\dot{Z}}_{F}\hat{D}_{r}(\tilde{\unicode[STIX]{x1D701}})}{4(\unicode[STIX]{x1D706}_{h}+\hat{D}_{r}(\tilde{\unicode[STIX]{x1D701}}))^{3}}\,\text{d}\tilde{\unicode[STIX]{x1D701}}+\frac{\unicode[STIX]{x1D716}\unicode[STIX]{x1D700}_{1}\unicode[STIX]{x1D700}_{2}}{16\unicode[STIX]{x1D6FF}}\frac{{\dot{Z}}_{F}}{Z_{F}}\frac{\unicode[STIX]{x1D706}_{h}-3\hat{D}_{r}}{(\unicode[STIX]{x1D706}_{h}+\hat{D}_{r})^{3}}\frac{\unicode[STIX]{x2202}\hat{D}_{r}}{\unicode[STIX]{x2202}\unicode[STIX]{x1D701}}, & & \displaystyle \nonumber\\ \displaystyle & & \displaystyle\end{eqnarray}$$
where we have denoted the time derivative of the front location
 $Z_{F}$
by
 ${\dot{Z}}_{F}$
. The contributions of the terms of (4.16) are on the left-hand side: bending and tension forces, and on the right-hand side: viscous pressure drop and shear forces.
4.2.1 The bending–tension regime
 $\unicode[STIX]{x1D706}_{h}\gg (\unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}})^{1/3}$

When
 $\unicode[STIX]{x1D706}_{h}\gg (\unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}})^{1/3}$
a dominant balance is achieved between the bending and tension terms of (4.16) on the length scale of
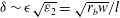 $\unicode[STIX]{x1D6FF}\sim \unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}}=\sqrt{r_{b}w}/l$
. In the prewetting thickness range
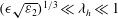 $(\unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}})^{1/3}\ll \unicode[STIX]{x1D706}_{h}\ll 1$
a uniform approximation matching the interior profile (4.9) to the boundary layer solution can be attained in closed form. To this end we define
 $\hat{D}_{r}=T^{-1/5}\hat{D}_{r,1}$
and
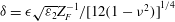 $\unicode[STIX]{x1D6FF}=\unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}}Z_{F}^{-1}/[12(1-\unicode[STIX]{x1D708}^{2})]^{1/4}$
. Equation (4.16) reduces to,
 $$\begin{eqnarray}\displaystyle \frac{\text{d}^{4}\hat{D}_{r,1}}{\text{d}\unicode[STIX]{x1D701}^{4}}+\hat{D}_{r,1}\sim \unicode[STIX]{x1D6FD}\int _{0}^{\unicode[STIX]{x1D701}}\hat{D}_{r,1}, & & \displaystyle\end{eqnarray}$$
where
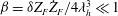 $\unicode[STIX]{x1D6FD}=\unicode[STIX]{x1D6FF}Z_{F}{\dot{Z}}_{F}/4\unicode[STIX]{x1D706}_{h}^{3}\ll 1$
. The right-hand side of (4.17) must be retained in order to meet the boundary conditions at the front. These will be assumed as follows:
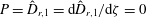 $P=\hat{D}_{r,1}=\text{d}\hat{D}_{r,1}/\text{d}\unicode[STIX]{x1D701}=0$
at
 $\unicode[STIX]{x1D701}=0$
. For large
 $\unicode[STIX]{x1D701}$
,
 $\hat{D}_{r,1}$
must be bounded and satisfy the matching condition,
 $$\begin{eqnarray}\displaystyle \lim _{\unicode[STIX]{x1D701}\rightarrow \infty }\hat{D}_{r,1}(\unicode[STIX]{x1D701})=\lim _{\unicode[STIX]{x1D709}\rightarrow 1}\unicode[STIX]{x1D702}_{_{F}}^{2/3}F(\unicode[STIX]{x1D709}), & & \displaystyle\end{eqnarray}$$
where
 $F$
and
 $\unicode[STIX]{x1D702}_{_{F}}$
correspond to the self-similar profile of (4.9) defined in (4.3). The asymptotic solution of (4.17) reads,
 $$\begin{eqnarray}\displaystyle \hat{D}_{r,1} & {\sim} & \displaystyle (2\unicode[STIX]{x1D6FF})^{1/3}\text{e}^{\unicode[STIX]{x1D6FD}\unicode[STIX]{x1D701}}-(2\unicode[STIX]{x1D6FF})^{1/3}\exp \left[-\left(\frac{1}{\sqrt{2}}+\frac{\unicode[STIX]{x1D6FD}}{4}\right)\unicode[STIX]{x1D701}\right]\nonumber\\ \displaystyle & & \displaystyle \times \left[(1+\sqrt{2}\unicode[STIX]{x1D6FD})\sin \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)+\cos \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\right].\end{eqnarray}$$
We cannot match the boundary layer and interior profiles in a straightforward manner due to the difference in functional form. In order to pursue a matched uniform solution we define the auxiliary problem,
 $$\begin{eqnarray}\displaystyle \frac{\text{d}^{4}\hat{D}_{r,1}^{a}}{\text{d}\unicode[STIX]{x1D701}^{4}}+\hat{D}_{r,1}^{a}\sim (2\unicode[STIX]{x1D6FF})^{1/3}\unicode[STIX]{x1D701}^{1/3}, & & \displaystyle\end{eqnarray}$$
which differs from (4.17) by the small orders
 $O(\unicode[STIX]{x1D6FD},\unicode[STIX]{x1D6FF}^{1/3})$
. The solution of (4.20) reads,
 $$\begin{eqnarray}\displaystyle \hat{D}_{r,1}^{a}=\hat{F}_{p}(\unicode[STIX]{x1D701})-\text{e}^{-\unicode[STIX]{x1D701}/\sqrt{2}}\left[\left(\hat{F}_{p}(0)+\sqrt{2}\frac{\text{d}\hat{F}_{p}(0)}{\text{d}\unicode[STIX]{x1D701}}\right)\sin \frac{\unicode[STIX]{x1D701}}{\sqrt{2}}+\hat{F}_{p}(0)\cos \frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right], & & \displaystyle\end{eqnarray}$$
and the particular solution
 $\hat{F}_{p}$
is given in appendix B. The auxiliary variable
 $\hat{D}_{r,1}^{a}$
satisfies (4.18) exactly and can be matched in closed form to the interior profile. A leading-order uniform approximation
 $D_{r}^{u}$
can be written in the original variables,
 $$\begin{eqnarray}\displaystyle & & \displaystyle \!\!D_{r}^{u}(Z,T)=T^{-1/5}\left[\left(1-\frac{L_{1}^{2}}{4}\right)_{+}^{1/3}-(2-L_{1})_{+}^{1/3}\right]+T^{-1/5}\hat{F}_{p}(KL_{2})\nonumber\\ \displaystyle & & \displaystyle -\,T^{-1/5}\exp \left(-\frac{KL_{2}}{\sqrt{2}}\right)\left[(\hat{F}_{p}(0)+\sqrt{2}{\hat{F}_{p}}^{\prime }(0))\sin \left(\frac{KL_{2}}{\sqrt{2}}\right)+\hat{F}_{p}(0)\cos \left(\frac{KL_{2}}{\sqrt{2}}\right)\right],\qquad \quad\end{eqnarray}$$
where
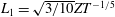 $L_{1}=\sqrt{3/10}ZT^{-1/5}$
,
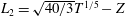 $L_{2}=\sqrt{40/3}T^{1/5}-Z$
and
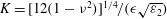 $K=[12(1-\unicode[STIX]{x1D708}^{2})]^{1/4}/(\unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}})$
. The solution is plotted in figure 5 at
 $T=T_{b}(\unicode[STIX]{x1D6FC}=1/5)$
, where transition from a tension dominant to a bending–tension regime is illustrated for two axial length scales
 $\unicode[STIX]{x1D6FF}=0.005,0.01$
(wall thickness and aspect ratios are adjusted accordingly). The uniform solution converges to the ZKB profile (4.9) as
 $T\rightarrow \infty$
. The convergence of the uniform solution (4.22) to the exact unmatched boundary layer solution (4.19) near the contact line is shown in figure 6 for various values of
 $\unicode[STIX]{x1D6FD}$
.
Uniform closed-form solution of a propagating elastohydrodynamic front for impulse-type boundary condition (4.8) and
 $\unicode[STIX]{x1D6FF}^{1/3}\ll \unicode[STIX]{x1D706}_{h}\ll 1$
. Snapshot of
 $D_{r}^{u}(Z,T_{b})$
for
 $\unicode[STIX]{x1D6FF}=0.01$
(red),
 $\unicode[STIX]{x1D6FF}=0.005$
(coral) and corresponding boundary layer solutions (4.21) (dashed lines). The interior profile
 $\unicode[STIX]{x1D702}_{_{F}}^{5/3}F(Z)$
(4.9) is plotted in black.

Convergence of the uniform solution (4.22) to the unmatched boundary layer solution (4.19) near the contact line. (a) The self-similar profile
 $D_{r}^{u}(\unicode[STIX]{x1D701})/T^{-1/5}\unicode[STIX]{x1D6FF}^{1/3}$
(solid red) is plotted against the boundary layer coordinate
 $\unicode[STIX]{x1D701}$
for
 $\unicode[STIX]{x1D6FD}=0.1$
(dashed),
 $\unicode[STIX]{x1D6FD}=0.12$
(dotted). (b) Magnification of the region
 $0\leqslant \unicode[STIX]{x1D701}\leqslant$
1,
 $D_{r}^{u}(\unicode[STIX]{x1D701})/T^{-1/5}\unicode[STIX]{x1D6FF}^{1/3}$
(solid red) versus
 $\unicode[STIX]{x1D701}$
for
 $\unicode[STIX]{x1D6FD}=0.1$
(dashed),
 $\unicode[STIX]{x1D6FD}=0.05$
(dashed-dotted).

At larger prewetting scales the effect of the boundary layer adjustment will diminish but will still impose shape modifications near the edge, due to the change in regime. A numerical solution and matching of the interior (e.g. (4.14)) and boundary layer (4.17) regions is required to describe this behaviour. A similar problem was addressed in the late time spreading of an elastic plated gravity current (Hewitt et al. Reference Hewitt, Balmforth and De Bruyn2015).
4.2.2 Smaller scales of the prewetting thickness
$\unicode[STIX]{x1D706}_{h}\ll (\unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}})^{1/3}$

We return to the dominant balance of equation (4.16). When
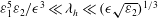 $\unicode[STIX]{x1D700}_{1}^{5}\unicode[STIX]{x1D700}_{2}/\unicode[STIX]{x1D716}^{3}\ll \unicode[STIX]{x1D706}_{h}\ll (\unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}})^{1/3}$
bending forces will balance viscous forces on the length scale of
 $\unicode[STIX]{x1D6FF}\sim (\unicode[STIX]{x1D716}^{4}\unicode[STIX]{x1D700}_{2}^{2}\unicode[STIX]{x1D706}_{h}^{3})^{1/5}$
while shear forces remain negligible. This regime describes the early stages of fluid injection at the inlet, for which
 $Z_{F}\ll \sqrt{r_{b}w}/l$
, and is analogous to the early time spreading of an elastic Hele-Shaw cell (Lister et al.
Reference Lister, Peng and Neufeld2013) or the pure bending regime of an elastic plated gravity current as described by Hewitt et al. (Reference Hewitt, Balmforth and De Bruyn2015). We note that the assumptions on the boundary conditions near the contact line (solution of (4.17)) no longer hold at smaller prewetting thicknesses as discussed herein.
When
 $\unicode[STIX]{x1D706}_{h}\ll \unicode[STIX]{x1D700}_{1}^{5}\unicode[STIX]{x1D700}_{2}/\unicode[STIX]{x1D716}^{3}$
bending forces will balance shear forces while viscous forces become negligible relative to these. However, the resulting axial length scale
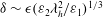 $\unicode[STIX]{x1D6FF}\sim \unicode[STIX]{x1D716}(\unicode[STIX]{x1D700}_{2}\unicode[STIX]{x1D706}_{h}^{2}/\unicode[STIX]{x1D700}_{1})^{1/3}$
is comparable with the shell thickness and hence we have reached the limit of the thin shell elastic model used in the analysis.
4.3 Designing deformation patterns with application to soft actuators
In this section we illustrate the use of the transport term
 $U_{0}\cdot \unicode[STIX]{x2202}D_{r}/\unicode[STIX]{x2202}Z$
of (3.34b
) and the relation between the speed of displacement propagation and the gap (
 $\unicode[STIX]{x1D706}_{h}$
), in order to obtain isolated moving deformations. The linear transport term may represent a relative motion of the rigid cylinder, or alternatively,
 $U_{0}(T)$
can be thought of as a slip velocity condition induced by an electric zeta potential or a similar mechanism.
The transported ZKB profile can be used as a building block for creating complex deformation patterns. Such mechanism may be useful for micro-swimmers (replacing complex mechanisms such as in Setter et al. Reference Setter, Bucher and Haber2012), as well as for soft-actuator and soft-robotic applications. Current soft robots commonly use multiple pressure inlets to compress various internal cavities and deform different parts of the robot (Tolley et al. Reference Tolley, Shepherd, Mosadegh, Galloway, Wehner, Karpelson, Wood and Whitesides2014; Marchese & Rus Reference Marchese and Rus2015). In a previous work (Elbaz & Gat Reference Elbaz and Gat2014) we suggested applying a viscous fluid to increase the possible modes of deformation for a given channel geometry. In this section we suggest a soft actuator with an initially closed embedded cavity, where viscous peeling dynamics advancing into the channel will limit the deformation to the region behind the peeling front, thus isolating the deformed region. Furthermore, applying the transport term in combination with the inlet pressure enables the design of moving isolated deformation patterns, thus allowing to temporally activate and deactivate different regions of the actuator.
We incorporate a small prewetting layer
 $\unicode[STIX]{x1D706}_{h}\ll 1$
, and focus on the tensile–viscous regime, neglecting boundary layer regularization for the moment. Equation (3.34b
) is then simply,
 $$\begin{eqnarray}\displaystyle \frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}T}+24U_{0}\frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}Z}\sim 4\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}Z}\left\{\frac{\unicode[STIX]{x2202}D_{r}}{\unicode[STIX]{x2202}Z}(\unicode[STIX]{x1D706}_{h}+D_{r})^{3}\right\}. & & \displaystyle\end{eqnarray}$$
At the left boundary we employ an impulse sequence of the form,
 $$\begin{eqnarray}\displaystyle D_{r}(0,T)=\mathop{\sum }_{n=0}^{N}A_{n}\left[\unicode[STIX]{x1D6E9}\left(T+\frac{\unicode[STIX]{x0394}T_{n}}{2}-\unicode[STIX]{x1D70F}_{n}\right)-\unicode[STIX]{x1D6E9}\left(T-\frac{\unicode[STIX]{x0394}T_{n}}{2}-\unicode[STIX]{x1D70F}_{n}\right)\right], & & \displaystyle\end{eqnarray}$$
where
 $\unicode[STIX]{x1D6E9}$
is the Heaviside function. The signal is modulated in amplitude,
 $A_{n}$
, and in width
 $\unicode[STIX]{x0394}T_{n}$
and can be sequenced non-uniformly by
 $\unicode[STIX]{x1D70F}_{n}$
. We set a zero initial condition and a no-flux condition at the right boundary,
 $$\begin{eqnarray}\displaystyle D_{r}(Z,0)=0,\quad \frac{\unicode[STIX]{x2202}D_{r}(1,T)}{\unicode[STIX]{x2202}Z}=0. & & \displaystyle\end{eqnarray}$$
Under the above conditions, a sequence of symmetric ZKB profiles will propagate through the interface. Assuming sufficiently small
 $\unicode[STIX]{x1D706}_{h}$
, each pulse will propagate independently. The rate of diffusion of the profiles decays strongly beneath a certain amplitude (determined by (3.35)) and is significantly slower than the rate of their transport, that is, they maintain their forms as they are transported. Using this approach, isolated fluid segments can be generated arbitrarily and transported along the interface independent of the pressure gradient and having limited or negligible communication with each other. In particular, the boundary sequence (4.24) can be modulated to form a moving wave signal, as illustrated in figure 7 via numerical solution of (4.23)–(4.25). A prewetting layer of
 $\unicode[STIX]{x1D706}_{h}=0.15$
was used with a constant rigid cylinder motion of
 $U_{0}=2$
. Figure 7(b) shows
 $3$
progressive snapshots of the resulting radial deformation wave as it propagates the interface. The corresponding contour plot is given in figure 7(a) and shows the uniformity of the sequence beyond an early generation time,
 $T>7\times 10^{-3}$
. The obtained solution closely approximates the waveform,
 $$\begin{eqnarray}\displaystyle D_{r}(Z,T)\approx \frac{A}{2}[1+\sin (KZ-\unicode[STIX]{x1D6FA}T)],\quad \frac{\unicode[STIX]{x1D6FA}}{K}=\frac{U_{0}}{2}, & & \displaystyle\end{eqnarray}$$
where
 $A=0.1$
and
 $K=\unicode[STIX]{x1D6FA}=10\unicode[STIX]{x03C0}$
.
Moving wave deformation pattern generated via a modulated impulse sequence (4.24). A prewetting layer of
 $\unicode[STIX]{x1D706}_{h}=0.15$
is used upon constant rigid cylinder motion of
 $U_{0}=2$
. Modulation laws in the interval
 $0\leqslant T\leqslant 0.02$
:
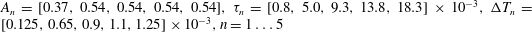 $A_{n}=[0.37,0.54,0.54,0.54,0.54],\unicode[STIX]{x1D70F}_{n}=[0.8,5.0,9.3,13.8,18.3]\times 10^{-3},\unicode[STIX]{x0394}T_{n}=[0.125,0.65,0.9,1.1,1.25]\times 10^{-3},n=1\ldots 5$
. (a) Fluid pressure contour in space and time. (b) Three progressive snapshots of the radial deformation wave at times
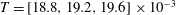 $T=[18.8,19.2,19.6]\times 10^{-3}$
, as it propagates the interface.

5 Concluding remarks
The analysis presented here assumes several small parameters, including geometric requirements such as
 $\unicode[STIX]{x1D700}_{2}=w/r_{i}\ll 1$
and dynamic physical requirements such as small deformations
 $\unicode[STIX]{x1D700}_{3}=d_{r}^{\ast }/r_{b}\ll 1$
and negligible inertia
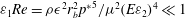 $\unicode[STIX]{x1D700}_{1}Re=\unicode[STIX]{x1D70C}\unicode[STIX]{x1D716}^{2}r_{b}^{2}{p^{\ast }}^{5}/\unicode[STIX]{x1D707}^{2}(E\unicode[STIX]{x1D700}_{2})^{4}\ll 1$
. While the geometric requirements are given and constant for a specific configuration, the physical requirements depend on, and limit, the magnitude of the characteristic driving pressure. To illustrate the maximal allowable pressures and characteristic time scales we examine several configurations with constant geometric ratios
 $\unicode[STIX]{x1D716}=\unicode[STIX]{x1D700}_{2}=0.1$
. For water (
 $\unicode[STIX]{x1D707}=10^{-3}~(\text{Pa}~\text{s})$
,
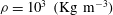 $\unicode[STIX]{x1D70C}=10^{3}~(\text{Kg}~\text{m}^{-3})$
) as the liquid and rubber (
 $E=10^{9}$
(Pa)) as the tube, we obtain
 $p^{\ast }=10^{4}$
(Pa),
 $t^{\ast }=10^{4}$
(s) in the case of
 $r_{b}=1$
(m) and
 $p^{\ast }=6.3\times 10^{4}$
(Pa),
 $t^{\ast }=4$
(s) in the case of
 $r_{b}=10^{-2}$
(m). For silicon oil (
 $\unicode[STIX]{x1D707}=10~(\text{Pa}~\text{s})$
,
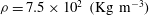 $\unicode[STIX]{x1D70C}=7.5\times 10^{2}~(\text{Kg}~\text{m}^{-3})$
) and rubber (
 $E=10^{9}$
(Pa)), we obtain
 $p^{\ast }=4.2\times 10^{5}$
(Pa),
 $t^{\ast }=10^{2}$
(s) in the case of
 $r_{b}=1$
(m) and
 $p^{\ast }=2.6\times 10^{6}$
(Pa),
 $t^{\ast }=0.5$
(s) in the case of
 $r_{b}=10^{-2}$
(m). Hence, a wide range of characteristic driving pressures and time scales can be achieved by varying the properties of the configuration. Unlike the linear elastohydrodynamics examined in Elbaz & Gat (Reference Elbaz and Gat2014), the assumption of creeping flow in the current problem can be achieved for any configuration, as long as
 $p^{\ast }$
and
 $\unicode[STIX]{x1D706}_{h}$
are sufficiently small.
Future research may include the effect of varying tube wall thickness, which is similar to spatially varying surface tension, and may allow for transport of isolated deformations without external mechanisms such as presented in § 4.3.
Acknowledgement
We are grateful for the generous financial support of TASP – Max & Rachel Javit fund.
Appendix A. Summary of results in dimensional form
Governing equations of the elastohydrodynamics in fluid pressure
 $p$
and elastic radial deformation
 $d_{r}$
, corresponding to (3.34),
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{Ew^{3}}{12(1-\unicode[STIX]{x1D708}^{2})}\frac{\unicode[STIX]{x2202}^{4}d_{r}}{\unicode[STIX]{x2202}z^{4}}-\frac{1}{2}\left[\frac{\unicode[STIX]{x1D707}wu_{0}}{(h_{0}+d_{r})^{2}}-\frac{w}{2}\frac{\unicode[STIX]{x2202}p}{\unicode[STIX]{x2202}z}\right]\frac{\unicode[STIX]{x2202}d_{r}}{\unicode[STIX]{x2202}z}+\frac{Ew}{r_{b}^{2}}d_{r}-\frac{w(h_{0}+d_{r})}{4}\frac{\unicode[STIX]{x2202}^{2}p}{\unicode[STIX]{x2202}z^{2}}\sim p,\qquad & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \frac{\unicode[STIX]{x2202}d_{r}}{\unicode[STIX]{x2202}t}-\frac{1}{12\unicode[STIX]{x1D707}}\frac{\unicode[STIX]{x2202}}{\unicode[STIX]{x2202}z}\left\{\frac{\unicode[STIX]{x2202}p}{\unicode[STIX]{x2202}z}(h_{0}+d_{r})^{3}\right\}+\frac{u_{0}}{2}\frac{\unicode[STIX]{x2202}d_{r}}{\unicode[STIX]{x2202}z}\sim 0. & \displaystyle\end{eqnarray}$$
Interior tensile–viscous regime solution of impulse driven propagation according to self-similarity, corresponding to (4.9),
 $$\begin{eqnarray}\displaystyle d_{r}(z,t)=\frac{{p^{\ast }}^{2/5}r_{b}^{^{6/5}}(48\unicode[STIX]{x1D707}l^{2})^{1/5}}{(Ew)^{3/5}}t^{-1/5}\left[1-\frac{3}{40}\left(\frac{48(Ew)^{2}\unicode[STIX]{x1D707}}{{p^{\ast }}^{3}l^{3}r_{b}^{4}}\right)^{2/5}z^{2}t^{-2/5}\right]_{+}^{1/3}, & & \displaystyle\end{eqnarray}$$
where
 $(s)_{_{+}}=\max (s,0)$
.
Self-similar propagation laws for inlet signals of type (4.5), corresponding to (4.10),
 $$\begin{eqnarray}\displaystyle & \displaystyle z_{_{F}}(t,\unicode[STIX]{x1D6FC})=l\left(\frac{{p^{\ast }}^{3}r_{b}^{4}t}{48\unicode[STIX]{x1D707}l^{2}(Ew)^{2}}\right)^{(1-3\unicode[STIX]{x1D6FC})/2}\unicode[STIX]{x1D702}_{_{F}}(\unicode[STIX]{x1D6FC}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle v(t,\unicode[STIX]{x1D6FC})=2\unicode[STIX]{x03C0}r_{b}^{2}l(48)^{(5\unicode[STIX]{x1D6FC}-1)/2}\left(\frac{Ew}{r_{b}}\right)^{5\unicode[STIX]{x1D6FC}-2}{p^{\ast }}^{(5-15\unicode[STIX]{x1D6FC})/2}\left(\frac{t}{\unicode[STIX]{x1D707}}\right)^{(1-5\unicode[STIX]{x1D6FC})/2}Q(\unicode[STIX]{x1D6FC}), & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle t_{b}(\unicode[STIX]{x1D6FC})=\frac{48\unicode[STIX]{x1D707}l^{2}(Ew)^{2}}{{p^{\ast }}^{3}r_{b}^{4}}\unicode[STIX]{x1D702}_{_{F}}(\unicode[STIX]{x1D6FC})^{-2/(1-3\unicode[STIX]{x1D6FC})}. & \displaystyle\end{eqnarray}$$
 $v$
is the interface volume.
Appendix B. Particular solution of (4.20)
 $$\begin{eqnarray}\displaystyle \hat{F}_{p}(\unicode[STIX]{x1D701}) & = & \displaystyle \frac{\unicode[STIX]{x1D6FF}^{1/3}}{\sqrt{2}}\left\{(-1+\text{i})(-1-\text{i})^{2/3}\exp \left(-\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\cos \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\hat{\unicode[STIX]{x1D6E4}}\left(\frac{4}{3},-\frac{(1+\text{i})\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\right.\nonumber\\ \displaystyle & & \displaystyle +\,(-1-\text{i})(-1+\text{i})^{2/3}\exp \left(-\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\cos \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\hat{\unicode[STIX]{x1D6E4}}\left(\frac{4}{3},-\frac{(1-\text{i})\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\nonumber\\ \displaystyle & & \displaystyle +\,(1+\text{i})(1-\text{i})^{2/3}\exp \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\cos \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\hat{\unicode[STIX]{x1D6E4}}\left(\frac{4}{3},\frac{(1-\text{i})\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\nonumber\\ \displaystyle & & \displaystyle +\,(1-\text{i})(1+\text{i})^{2/3}\exp \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\cos \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\hat{\unicode[STIX]{x1D6E4}}\left(\frac{4}{3},\frac{(1+\text{i})\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\nonumber\\ \displaystyle & & \displaystyle -\,(1+\text{i})^{5/3}\exp \left(-\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\sin \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\hat{\unicode[STIX]{x1D6E4}}\left(\frac{4}{3},-\frac{(1+\text{i})\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\nonumber\\ \displaystyle & & \displaystyle -\,(1-\text{i})^{5/3}\exp \left(-\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\sin \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\hat{\unicode[STIX]{x1D6E4}}\left(\frac{4}{3},-\frac{(1-\text{i})\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\nonumber\\ \displaystyle & & \displaystyle +\,(1-\text{i})^{5/3}\exp \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\sin \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\hat{\unicode[STIX]{x1D6E4}}\left(\frac{4}{3},\frac{(1-\text{i})\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\nonumber\\ \displaystyle & & \displaystyle +\,\left.(1+\text{i})^{5/3}\exp \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\sin \left(\frac{\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\hat{\unicode[STIX]{x1D6E4}}\left(\frac{4}{3},\frac{(1+\text{i})\unicode[STIX]{x1D701}}{\sqrt{2}}\right)\right\}\end{eqnarray}$$
where
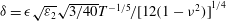 $\unicode[STIX]{x1D6FF}=\unicode[STIX]{x1D716}\sqrt{\unicode[STIX]{x1D700}_{2}}\sqrt{3/40}T^{-1/5}/[12(1-\unicode[STIX]{x1D708}^{2})]^{1/4}$
and
 $\hat{\unicode[STIX]{x1D6E4}}$
is the upper incomplete gamma function.



