



1. Introduction
Fish have perfected underwater swimming over evolutionary time scales. They have different locomotion depending on body structure and habitat. Theoretical and experimental studies on fish-like propulsion of rigid and flexible foils with simple pitching, heaving and undulatory motions have been studied in the literature. The propulsion efficiency of a rigid foil undergoing pitching or heaving motion is quite low, whereas a high propulsive efficiency can be achieved when both pitching and heaving motions are simultaneously involved (von Kármán & Burgers Reference von Kármán and Burgers1934). The reason for the low thrust and efficiency of a pitching foil, compared with a pitching and heaving foil, is the formation of a relatively narrow jet in the wake. In other words, the proximity of reverse Kármán vortices close to the symmetry line inhibits the thickening of the wake jet (Hanchi et al. Reference Hanchi, Benkherouf, Mekadem, Oualli, Keirsbulck and Labraga2013).
The literature largely focused on the wake structure of rigid pitching propulsors. Depending on the thickness-based pitching Strouhal number Std (= fd/U∞, where f is the oscillation frequency, d is the maximum width of the foil and U∞ is the freestream velocity) and amplitude ratio A* (= A/d, where A is the peak-to-peak amplitude of the pitching), the wake structure of a sinusoidal pitching foil ranges from a simple 2S wake (two single vortices shed in an oscillation cycle) to a complex 8P wake (eight pairs of vortices shed in one oscillation cycle) as observed for thickness-based Reynolds number Red (= ρU∞d/μ) = 220 and 440 (Schnipper, Andersen & Bohr Reference Schnipper, Andersen and Bohr2009), where ρ and μ are the density and the dynamic viscosity of the fluid, respectively. The complex wake occurs at Std < 0.05 while a 2P + 2S (two pairs and two single vortices shed in an oscillation cycle) or 2P (two pairs of vortices shed per oscillation cycle) wake prevails at 0.05 < Std < 0.1 and a 2S wake persists at 0.1 < Std < 0.3. The 2S Kármán vortex wake is predominant at low A*, whereas a 2S reverse Kármán wake emerges at high A* with amplitude-based Strouhal number StA (= fA/U∞) > 0.18. Two rows of opposite sign vortices (Kármán vortex street) feature in the wake when Std and/or A* of a foil is small. An increase in Std and/or A* makes the two vortex rows aligned on the wake centreline, which is called a 2S aligned wake. With a further increase in either Std or A*, two vortex rows distance from the wake centreline, the vortex rotation signs being opposite to the Kármán vortex street. It is thus known as a reverse Kármán vortex street where the rotation sense of vortices in the two rows produces a jet along the wake centreline. At a high Std (>0.2) and a high A* (>1.6), the wake becomes asymmetric, and is deflected away from the wake centreline (see figure 3 of Godoy-Diana, Aider & Wesfreid Reference Godoy-Diana, Aider and Wesfreid2008) at Red = 255. Using stability analysis of pitching NACA0015 foil at Red = 255, Deng, Sun & Shao (Reference Deng, Sun and Shao2015) showed that the deflection of the wake occurs when the flow transits from two-dimensional (2-D) to three-dimensional (3-D). Moriche, Flores & García-Villalba (Reference Moriche, Flores and García-Villalba2016) conducting 2-D and 3-D simulations of a pitching and plunging NACA0012 foil at chord-based Reynolds number Rec (= ρU∞c/μ) = 1000 found that the near-wake structures obtained from 2-D and 3-D simulations are similar to each other. Additionally, differences in the aerodynamic forces between the 2-D and the 3-D simulations were less than 5 %. Alam & Muhammad (Reference Alam and Muhammad2020) also compared results between 2-D and 3-D simulations at Red = 200 and found that the flow around the oscillating foil at Red = 200 is essentially 2-D. The maximum instantaneous thrust is generated at the instant where the rate of power input changes from positive to negative, i.e. at the inflection point of the power curve. The instantaneous thrust leads the instantaneous power. They analysed the fluid dynamics based on inertia, using relative angular acceleration with respect to the foil showing that the fluid dynamics is strongly dictated by the inertia of the foil. They mathematically developed a flow model based on Euler, Coriolis and centrifugal accelerations in a non-inertial frame to assimilate the physical insight into the thrust generation and power input. While Euler and Coriolis accelerations were involved in the power input, the centrifugal acceleration was linked to the thrust generation. The normal and reverse Kármán wakes were found to be the attributes of the drag and thrust, respectively, but not the origin of the thrust.
The early experimental studies on pitching foil focused on wake structure and time-averaged forces. The forces were estimated from the momentum balance. It led to an overestimation when unsteady terms (e.g. streamwise velocity fluctuations and pressure) are neglected (Bohl & Koochesfahani Reference Bohl and Koochesfahani2009). The inclusion of the unsteady terms reasonably predicts the time-averaged forces on high pitching frequency foils whereas under predicts those on low pitching frequency foils (Mackowski & Williamson Reference Mackowski and Williamson2015).
The Std, A*, pitching centre and attack angle are all pivotal parameters for thrust generation and efficiency (Triantafyllou et al. Reference Triantafyllou, Hover, Techet and Yue2005; Alam & Muhammad Reference Alam and Muhammad2020). For a given angular amplitude of the foil oscillation, when the pitching centre moves from the leading edge to the foil tip (trailing edge), the amplitude of the foil tail shrinks and hence thrust drops (Tian et al. Reference Tian, Bodling, Liu, Wu, He and Hu2016). Interestingly, the experiments of Van Buren et al. (Reference Van Buren, Floryan, Wei and Smits2018) showed negligible effects of the free-stream velocity on the wake of a pitching foil at 4770 < Rec < 9550 examined. They noted that studies on foil undergoing a constant Rec could provide robust conclusions of the swimming performance of pitching foils without the need to explore the free-swimming condition. Similarly, a study of a pair of hovering (ascending and descending states) sinusoidal pitching thin foils also indicated that the effect of Rec is insignificant for Reynolds number larger than 1000 (Zhang et al. Reference Zhang, He, Wang and Zhang2018).
Several studies have reported increased thrust/efficiency of pitching foils with intermittent swimming motion (Videler Reference Videler1981; Akoz & Moored Reference Akoz and Moored2018) or with chord-wise flexibility (Marais et al. Reference Marais, Thiria, Wesfreid and Godoy-Diana2012; Egan, Brownell & Murray Reference Egan, Brownell and Murray2016; David, Govardhan & Arakeri Reference David, Govardhan and Arakeri2017; Huera-Huarte & Gharib Reference Huera-Huarte and Gharib2017). The waveform of the body motion also affects thrust and efficiency. For example, clapping wings have a lower efficiency than pitching wings (Martin et al. Reference Martin, Roh, Idrees and Gharib2017) and non-sinusoidal pitching motion enhances thrust or efficiency (Xiao & Liao Reference Xiao and Liao2009; Lu, Xie & Zhang Reference Lu, Xie and Zhang2013; Xie et al. Reference Xie, Lu, Zhang and Xie2014; Chao et al. Reference Chao, Pan, Zhang and Yan2019). There are two different types of non-sinusoidal motions studied in the literature (figure 1a,b). The first category is based on shifting the peaks toward (dash–dotted line) or away (solid line) from the midpoint (t = T/2, where t is the time and T is the oscillation period) compared with the peaks for the sinusoidal motion (dashed line) (figure 1a). A motion trajectory of this category is asymmetric about the peaks but second-order rotational symmetric about point t = T/2. It is here termed as a quasi-symmetric waveform. It could be simply described as a faster movement from the lower extreme to the upper extreme than from the upper extreme to the lower extreme (solid line) and vice versa (dash–dotted line). The foil undergoing this kind of motion sheds one stronger vortex in the faster stroke and multiple weaker vortices in the slower stroke (Koochesfahani Reference Koochesfahani1989). This motion generates higher thrust and lower efficiency than purely sinusoidal motion (Xiao & Liao Reference Xiao and Liao2009). The second category of non-sinusoidal pitching motion is the blend of square and sawtooth waveforms (figure 1b). These waveforms are symmetric about the peaks, having the second-order rotational symmetry about the point t = T/2, where the change in the blending factor can gradually modify the sinusoidal waveform (dashed line) to a nearly square waveform (dash–dotted line) or to a sawtooth (solid line). The thrust beefs up but the efficiency declines when the sinusoidal waveform is modified to a square waveform. However, the modification of the sinusoidal waveform to a sawtooth waveform cuts down the thrust but enhances the efficiency (Lu et al. Reference Lu, Xie and Zhang2013; Xie et al. Reference Xie, Lu, Zhang and Xie2014). A waveform with a higher maximum pitch rate (maximum  $\dot{\theta }( = \textrm{d}\theta /\textrm{d}t)$, where θ is the instantaneous pitch angle) generates stronger vortices. The boundaries of the drag–thrust transition, deflected wake transition and three-dimensional wake transition appear earlier in the Std–A* plane for square wave motion than for sawtooth wave motion (Chao et al. Reference Chao, Pan, Zhang and Yan2019).
The pitching motions studied in the literature include (a) quasi-symmetric waveforms (Koochesfahani Reference Koochesfahani1989; Xiao & Liao Reference Xiao and Liao2009) and (b) symmetric waveforms (Lu et al. Reference Lu, Xie and Zhang2013; Xie et al. Reference Xie, Lu, Zhang and Xie2014) from nearly square wave (dash–dotted line) to sawtooth wave (solid line). (c) The proposed asymmetric waveform.

The above literature on the pitching foils investigated the wake patterns, drag–thrust transition, time-average thrust and efficiency. Compared with the sinusoidal waveform, the non-sinusoidal waveforms investigated in the literature resulted in a higher thrust and a lower efficiency in most cases or a lower thrust and a higher efficiency in the other cases. It is thus challenging to enhance both thrust and efficiency at the same time. The drawback in the first category of waveforms (figure 1a) is that when a peak-to-peak stroke is made faster, the other stroke becomes slower, given a constant T. That is, if the faster stroke provides a better thrust, the slower stroke would worsen the thrust. The waveforms in the second category (figure 1b) display a peak-to-peak stroke that is the same as the other. The waveforms with higher pitch rates (e.g. nearly square waves) have higher thrust and lower efficiencies as compared to those with lower pitch rates (e.g. sawtooth wave). Note that in both categories, the motion in a peak-to-peak stroke has a second-order rotational symmetry about the point t = T/2. A perception of the two types of waveforms and their correspondence to the thrust and efficiency gives an idea that we should consider quarter-wise different strokes, e.g. a faster stroke from the equilibrium position to the extreme position and a slower stroke from the extreme position to the equilibrium position or vice versa (figure 1c). That is, a peak-to-peak stroke will have the first-order rotational symmetry about the point t = T/2, i.e. no symmetry. When animals and humans swim, their limb motion may not be sinusoidal, and the motion of their limbs from the equilibrium to the extreme and from the extreme to the equilibrium may not be symmetric. We expect slower motion in the stroke from the equilibrium to the extreme (forward stroke) and a faster motion in the stroke from the extreme to the equilibrium (retract stroke) (figure 1c). This novel waveform is examined in this work. The literature have neither presented information on thrust and efficiency for the individual strokes nor focussed on the relationship between the kinematics, wake, thrust, power and efficiency. The insight into the relationship between the kinematics and thrust or efficiency is thus not well understood. Understanding of kinematics and its correspondence to thrust and efficiency may lead us to discover a way for higher thrust and efficiency simultaneously with the new waveform.
The objective of this study is to: (i) enhance both thrust and efficiency without increasing the frequency and amplitude of the pitching foil; (ii) understand the associated fluid dynamic mechanism behind the thrust enhancement and (iii) study the link between the kinematics, forces and the wake. The objective (i) ‘enhancement of thrust and efficiency,’ although simple, has not been attempted in the literature. Various pitching motions studied in the literature could only achieve enhancement in either thrust or efficiency. The non-sinusoidal motions studied in the literature are either symmetric about the peak (figure 1b) or asymmetric about the same (figure 1a) but both have second-order rotational symmetry. We study here a new motion (inspired by nature) that is asymmetric about both peak and equilibrium position (t = T/2) (figure 1c). The instantaneous input power and thrust generated owing to an asymmetric pitching foil are analysed and compared with those of the sinusoidal pitching foil. Furthermore, how the asymmetry of the motion influences the wake formation and size is presented in terms of vorticity evolution and wake width.
2. Methodology
2.1. Model and parameters
The foil is tear-shaped, with a semi-circular blunt leading edge and a tapered foil tip, extensively used in the literature (Godoy-Diana et al. Reference Godoy-Diana, Aider and Wesfreid2008, Reference Godoy-Diana, Marais, Aider and Wesfreid2009; Schnipper et al. Reference Schnipper, Andersen and Bohr2009; Marais et al. Reference Marais, Thiria, Wesfreid and Godoy-Diana2012; Andersen et al. Reference Andersen, Bohr, Schnipper and Walther2016; Alam & Muhammad Reference Alam and Muhammad2020; and others). The chord (c) to thickness (d) ratio of the foil is c/d = 5.1, and the foil pitches about the centre (marked with a ‘+’ sign) of the semi-circular leading edge (figure 2a). The peak-to-peak amplitude is defined by A. Figure 2(b) shows sign conventions of forces (thrust and lift), moment and power. Thrust is positive in the negative x-direction. Lift is considered positive in the y-direction while moment in the z-direction (counterclockwise rotation) is assumed positive. Power transferred from the body to the fluid is positive. The effect of gravity is ignored. The sinusoidal pitching motion can be described by amplitude and frequency. The dimensionless form of the amplitude is A* and that of the frequency is the Strouhal number Std, which lie in the ranges of 1.1–1.6 and 0.21–0.33, respectively. The A* is selected based on the natural range of the tail amplitude of various fish, as reported by Floryan et al. (Reference Floryan, Van Buren, Rowley and Smits2017), while Std is based on the natural swimmers (Godoy-Diana et al. Reference Godoy-Diana, Aider and Wesfreid2008; Alam & Muhammad Reference Alam and Muhammad2020). The corresponding StA (= Std × A*) nestles within the range observed in swimming animals, fish and cetacean (Triantafyllou, Triantafyllou & Gopalkrishnan Reference Triantafyllou, Triantafyllou and Gopalkrishnan1991; Taylor, Nudds & Thomas Reference Taylor, Nudds and Thomas2003; Eloy Reference Eloy2012).
(a) Geometry and dimensions of the foil. The dashed line shows the upper extreme position of the foil during pitching motion. (b) Positive directions for forces, moment and power. (c) Sinusoidal (solid line) and modified (dashed line) waveforms.

The foil is assumed to swim at constant Rec = 103. This Rec and the geometry used correspond to a velocity of 1.73 body lengths per second (BL/s), which is in the range of 0.5–3 BL/s for various species of fish reported by Floryan et al. (Reference Floryan, Van Buren, Rowley and Smits2017). The developed swimming robots, employing pitching motion of the body or tail, also lie in the same range, e.g. the average speed of the SoFi robot fish is 0.5 BL/s (Katzschmann et al. Reference Katzschmann, DelPreto, MacCurdy and Rus2018).
The inertial forces dominate the viscous forces for Rec ≫ 1, called the Eulerian regime (Childress Reference Childress1981). The bird and fish typically operate at Rec ≥ 102 (Raspa, Godoy-Diana & Thiria Reference Raspa, Godoy-Diana and Thiria2013). The Rec = 103 used in this study falls in the Eulerian regime. The flow around micro-air vehicles or small-unmanned underwater vehicles also lies in this regime. Moreover, Van Buren et al. (Reference Van Buren, Floryan, Wei and Smits2018) did experiments for pitching and pitching-and-heaving wings at Rec ~ 103–104, and reported that the forces on the body undergoing undulatory motion are dominated by the lateral velocity of the body, not by the free-stream flow velocity. In other words, the findings in this investigation can be applicable to a range of Rec.
2.2. Modified sine motion
Figure 2(c) shows a sine wave (solid line) and an asymmetric wave. The asymmetric wave is a combination of two sine waves of periods T 1 and T 2 (i.e. of different frequencies), respectively, such that the foil follows the wave of period T 1 when moving from the equilibrium position to the upper or lower extreme. However, it follows the wave of period T 2 when moving from the upper or lower extreme to the equilibrium position. Naturally, the time required for the foil to reach from the equilibrium to the extreme is T 1/4 and that from an extreme to the equilibrium is T 2/4, which yields the time-period of the modified sine wave T = (T 1 + T 2)/2. In other words, this trajectory is an evolution of the quasi-symmetric trajectory (figure 1a), the first category mentioned in the introduction. Recall that in the quasi-symmetric trajectory, the time for a half-cycle (from the lower extreme to the upper extreme) was different from that for the next half-cycle (from the upper extreme to the upper extreme), with a quarter period in a half-cycle being equal to the other quarter period in the same half-cycle. Now, in the present trajectory, a quarter period (e.g. from the extreme to the equilibrium) of a half-cycle is different from the other quarter period (from the equilibrium to the upper extreme) in the same half-cycle, with the time for a half-cycle (from the lower extreme to the upper) being essentially the same as that for the other half-cycle (from the upper extreme to the lower).
The degree of the asymmetry of the wave can be expressed by a time-period ratio  $(\mathrm{\mathbb{T}})$ as
 \begin{equation}\mathrm{\mathbb{T}} = \frac{{{T_1}}}{T}.\end{equation}
The T 1 = T 2 gives  $\mathrm{\mathbb{T}} = 1.00$, which indicates a purely sinusoidal wave, each quarter period being the same. When
 $\mathrm{\mathbb{T}} < 1.00$, the quarter stroke from the equilibrium to the extreme (referring to the ‘forward stroke’) is faster than the other quarter stroke from the extreme to the equilibrium (referring to the ‘retract stroke’). In contrast,
 $\mathrm{\mathbb{T}} > 1.00$ implies that the forward stroke is slower than the retract stroke. A discontinuity in the slope at the equilibrium position (figure 2c) is avoided by parametrizing the equation of foil motion in non-dimensional form as
 \begin{equation}\theta ^{\prime} = \sin 2{\rm \pi} l^{\prime},\end{equation}
where
 \begin{equation}t^{\prime} = l^{\prime} + {\textstyle{1 \over 4}}(\mathrm{\mathbb{T}} - 1){\sin ^2}2{\rm \pi} l^{\prime}.\end{equation}
In the above equations, θ′ (= θ/θmax) is the normalized instantaneous angular displacement of the foil, θmax is the angular amplitude in radians and the parameter l′ is the normalized dimensionless pseudo-time where l′ ∈ [0, 1]. The dimensionless time (t′ = t/T) depends on  $\mathrm{\mathbb{T}}$ (2.3) that is varied from 0.80 to 1.40 in this study, which covers most of the practical limits of
 $\mathrm{\mathbb{T}}$ (see Appendix A1). The use of pseudo-time to achieve a continuous function can be understood as compressing / stretching the time axis (Wald Reference Wald2010). The circular frequency of pitching ω ( = 2
 ${\rm \pi}$/T) is presented in non-dimensional form as ωl = 2
 ${\rm \pi}$l′ ((2.2) and (2.3)). The angular velocity
 $(\dot{\theta })$ and acceleration
 $(\ddot{\theta })$ can be obtained by applying the chain rule as
 \begin{equation}\dot{\theta } =
\frac{{\partial \theta ^{\prime}}}{{\partial t^{\prime}}} =
\frac{{\displaystyle\frac{{\partial \theta ^{\prime}}}{{\partial
l^{\prime}}}}}{{{{\displaystyle\frac{{\partial t^{\prime}}}{{\partial
l}^\prime}} }}} = \frac{{2{\rm \pi} \cos 2{\rm \pi} l^{\prime}}}
{{1 + \frac{{\rm \pi} }{2}(\mathrm{\mathbb{T}} - 1)\sin 4{\rm \pi} l^{\prime}}},\end{equation}
and
 \begin{equation}\ddot{\theta } ={-} \frac{{4{{\rm \pi} ^2}({\rm \pi} (\mathrm{\mathbb{T}} - 1){{\cos }^3}2{\rm \pi} l^{\prime} + \sin 2{\rm \pi} l^{\prime})}}{{{{\left( {1 + \frac{{\rm \pi} }{2}(\mathrm{\mathbb{T}} - 1)\sin 2{\rm \pi} l^{\prime}} \right)}^2}}}.\end{equation}
Equations (2.2), (2.4) and (2.5) for  $\mathrm{\mathbb{T}} = 1.00$ reduce to a simple sinusoidal motion. Figure 3(a) shows the modified sine motion for
 $\mathrm{\mathbb{T}} = 0.80- 1.40$. Clearly, when
 $\mathrm{\mathbb{T}} < 1.00$, the forward stroke is faster than the retract stroke and vice versa. Figure 3(b) shows the phase portrait of the modified sine motion, where the angular velocity is normalized as
 $\dot{\theta }^{\prime} = \dot{\theta }/{\dot{\theta }_{max}}$, where
 ${\dot{\theta }_{max}}$ is the maximum angular velocity in radians per second. The phase
 $\phi = {\tan ^{ - 1}}(\theta ^{\prime}/\dot{\theta }^{\prime})$ is marked in degrees along with the foil rotation marked by arrows at the leading edge. It can be appreciated mathematically from (2.2), (2.4) and (2.5) and visually from figure 3 that the pitching motions (shown in figure 3) are continuously differentiable contrary to those (dashed line) shown in figure 2(c). The phase portrait for the sine wave
 $(\mathrm{\mathbb{T}} = 1.00)$ is a unit circle, whereas the modified motions
 $(\mathrm{\mathbb{T}} \ne 1.00)$ display distorted circles (figure 3b). The information on time in the phase portrait can be inferred by magnitudes of
 $\dot{\theta }^{\prime}$ in a stroke. Compared with those for
 $\mathrm{\mathbb{T}} = 1.00$, higher magnitudes of
 $\dot{\theta }^{\prime}$ in a quarter (stroke) correspond to a shorter time in the quarter and vice versa. In addition, a longer arc length (in a quarter) complements a shorter time.
Modified sine motion in (a) waveforms and (b) phase portrait. Phase in degrees is marked in phase portrait, along with physical representation of the phase shown by small foil drawn along it. The arrow around the leading edge of the foil shows the instantaneous angular velocity direction.

2.3. Numerical set-up
Two-dimensional simulations of the unsteady, incompressible laminar flow are carried out. The non-dimensional continuity and Navier–Stokes (N-S) equations (in ANSYS Fluent) are solved using the finite-volume method (FVM), which can be written as
 \begin{equation}\nabla \boldsymbol{\cdot} {\boldsymbol{U}^{\ast} } = 0\end{equation}
and
 \begin{equation}\frac{{\partial {\boldsymbol{U}^{\ast} }}}{{\partial {t^\ast }}} + ({\boldsymbol{U}^\ast }\boldsymbol{\cdot }\boldsymbol{\nabla }){\boldsymbol{U}^\ast } ={-} \boldsymbol{\nabla }{P^\ast } + \frac{1}{{R{e_c}}}({\nabla ^2}{\boldsymbol{U}^\ast }),\end{equation}
where  ${\boldsymbol{U}^\ast }(x,y,t) = ({u^\ast },{v^\ast }) = (u,v)/{U_\infty }$ and
 ${P^\ast }(x,y,t) = P/\rho U_\infty ^2$ are the dimensionless velocity and pressure fields, respectively, and
 ${t^\ast } = t{U_\infty }/d$ is the non-dimensional time. The SIMPLE (Semi-Implicit Method for Pressure Linked Equations) segregated algorithm is used for pressure–velocity coupling and a second-order implicit scheme is used for the transient formulation. A structured mesh is used with the first cell height corresponding to y+ < 1, see p. 540 of White (Reference White2003) for the formula and calculation of y+. Figure 4(a) shows the computational domain and boundary conditions. A uniform inlet velocity (U∞) is imposed on the upstream boundary. The side walls are modeled as frictionless walls to restrict the formation of the boundary layer. The downstream boundary is modeled as the flow outlet. While the upstream and side boundaries are 50d away from the pitching centre of the hydrofoil, the downstream boundary stays 150d away from the same centre, the blockage ratio being 1 %. The x–y coordinate system is centred at the pitching center (figure 4a). The motion of the foil is governed by (2.1)–(2.5) coded and hooked to the main solver. The thrust
 $({C_T})$ and input power
 $({C_P})$ coefficients are calculated as
 \begin{equation}{C_T} = \frac{{ - 2 \times {F_x}}}{{\rho U_\infty ^2d}},\end{equation}
and
 \begin{equation}{C_P} = {C_{Pi}} + {C_{Pf}} = \frac{{{J_{zz}}\ddot{\theta }\dot{\theta }}}{{{\textstyle{1 \over 2}}\rho U_\infty ^3d}} + \frac{{ - {M_z}\dot{\theta }}}{{{\textstyle{1 \over 2}}\rho U_\infty ^3d}} = \frac{{2 \times ({J_{zz}}\ddot{\theta } - {M_z})\dot{\theta }}}{{\rho U_\infty ^3d}},\end{equation}
where Fx is the drag force on the foil (in the x-direction), Jzz is the mass moment of inertia of the foil (Jzz = 1 × 10⁻⁵ kg-m2, assuming the foil is made of titanium) and Mz is the flow-induced moment on the foil. The instantaneous power  ${C_P}$ given to the fluid–structure system accelerates not only the fluid but also the foil. The power consumed by the foil inertia is
 ${C_{Pi}} = {J_{zz}}\ddot{\theta }\dot{\theta }/{\textstyle{1 \over 2}}\rho U_\infty ^3d$ and that by the fluid is
 ${C_{Pf}} ={-} {M_z}\dot{\theta }/{\textstyle{1 \over 2}}\rho U_\infty ^3d$. The cycle averaged quantities can be obtained by integrating the above equations over a time duration nT (n = number of oscillation cycles) which can be expressed as
 \begin{equation}{\bar{C}_T} = \frac{1}{{nT}}\int_{{t_0}}^{{t_0} + nT} {{C_T}(t)\,\textrm{d}t} \quad \textrm{and}\quad {\bar{C}_P} = \frac{1}{{nT}}\int_{{t_0}}^{{t_0} + nT} {{C_P}(t)\,\textrm{d}t} ,\end{equation}
where  ${t_0}$ is the initial time, chosen after the solution converges.
(a) Computation domain (not to scale) and boundary conditions. (b) Comparison between the simulated (present) and experimental (Van Buren et al. Reference Van Buren, Floryan, Wei and Smits2018) results. (c) Complete grid and (d) close-up view of near-field grid (every sixth line is plotted in c and d).

Naturally and mathematically,
 \begin{equation}{\bar{C}_{Pi}} = \frac{1}{{nT}}\int_{{t_0}}^{{t_0} + nT} {{C_{Pi}}(t)\,\textrm{d}t} = \frac{1}{{nT}}\int_{{t_0}}^{{t_0} + nT} {\frac{{{J_{zz}}\ddot{\theta }\dot{\theta }}}{{{\textstyle{1 \over 2}}\rho U_\infty ^3d}}\textrm{d}t} = 0.\end{equation}
Therefore,  ${\bar{C}_P} = {\bar{C}_{Pf}}$, which implies that the time-averaged power input, thrust and efficiency all are independent of foil mass density or Jzz. The foil undergoes a forced motion, i.e. θ and its higher derivatives (
 $\dot{\theta }$ and
 $\ddot{\theta }$) are all independent of the material of foil (mass / density / Jzz) and the properties (ρ / υ) of the fluid (see (2.2)–(2.5)). From (2.9), we can see that
 ${C_{Pi}} \propto {J_{zz}}$, i.e. a higher mass moment of the inertia will result in a higher
 ${C_{Pi}}$. The qualitative variation of
 ${C_{Pi}}$ is independent of the material for a perfectly elastic storage system. Equations (2.9) and (2.10b) both account for negative
 ${C_P}$ (i.e.
 ${C_P} < 0$), which means that the foil receives/stores energy that can be used later. For non-elastic storage systems, we take only positive
 ${C_P}$ into consideration, i.e. no energy is stored by the foil. Following the literature (Berman & Wang Reference Berman and Wang2007; Ke et al. Reference Ke, Zhang, Cai and Chen2017; Wang, Goosen & Keulen Reference Wang, Goosen and Keulen2017), we define the coefficient of instantaneous positive power consumption as
 \begin{equation}C_P^{+} = C_{Pi}^ +{+} C_{Pf}^ + ,\end{equation}
where the  $C_{Pi}^ + $ and
 $C_{Pf}^ + $ are respectively the inertial and fluid components of the instantaneous positive power consumption
 $(C_P^ + )$. The positive power coefficient and its components are obtained by multiplying the respective coefficient / component with the signum of the
 ${C_P}$. The mathematical form of the positive power coefficient and its components is given as
 \begin{equation}C_X^ + = {C_X}{\mathop{\rm sgn}} ({C_P}),\end{equation}
where X is either P, Pi or Pf, giving  $C_P^ + $,
 $C_{Pi}^ + $ and
 $C_{Pf}^ + $, respectively. The time-averaged positive power coefficient can then be calculated as
 \begin{equation}\bar{C}_P^ + = \frac{1}{{nT}}\int_{{t_0}}^{{t_0} + nT} {C_P^ + \,\textrm{d}t} .\end{equation}
The Froude efficiency η for elastic systems is defined as the ratio of the thrust power  $( - \overline {{F_x}} {U_\infty })$ to the input power Pw, i.e.
 $\eta ={-} \overline {{F_x}} {U_\infty }/{P_w}$. It can be easily shown that η can be reduced as
 \begin{equation}\eta = \frac{{{{\bar{C}}_T}}}{{{{\bar{C}}_P}}}.\end{equation}
Note that thrust and thrust power after non-dimensionalization have the same numerical value and hence we prefer the above-mentioned form of η. Similarly, for non-elastic systems, the Froude efficiency η+ takes the form
 \begin{equation}{\eta ^ + } = \frac{{{{\bar{C}}_T}}}{{\bar{C}_P^ + }}\textrm{.}\end{equation}
2.4. Validation and mesh and time-step independence test
A moving/deforming mesh system rather than a re-meshing technique is used to accommodate the motion of the foil. The former has a consistent mesh size and ability to work with quadrilateral mesh (rather than triangular mesh), unarguably superior to the latter (Murayama, Yamamoto & Kobayashi Reference Murayama, Yamamoto and Kobayashi2006; Murayama & Yamamoto Reference Murayama and Yamamoto2008). However, for a moving/deforming mesh system, the time-advancement incurs additional calculations, including solving the deformations and positions for each node of the mesh for each time step. This invariably elongates the simulation time that can be reduced by increasing the time-step size. As expected, an increased time step deteriorates the solution accuracy but greatly reduces the solution convergence time. To achieve a balance between the solution accuracy and convergence time, a second-order implicit time integration scheme is used. Additionally, a relatively larger time step is used for the first 20T, which helped the solution converge faster, followed by a smaller time step to achieve time-accurate solution. Figure 4(c) shows the complete structured mesh system used. The mesh was divided into two parts, as shown in figure 4(d), separated by a non-conformal sliding interface shown by the red line. The inner part of the mesh (0.12 % of the total mesh area, inside the red circle in figure 4d) moved with the foil while the outer mesh was stationary. The first cell height normal to the foil surface was 0.004d, which is adequate for the numerical set-up used (Alam & Muhammad Reference Alam and Muhammad2020). A similar non-conformal sliding interface strategy has been employed in the literature, e.g. see Benkherouf et al. (Reference Benkherouf, Mekadem, Oualli, Hanchi, Keirsbulck and Labraga2011) for heaving motion and Hanchi et al. (Reference Hanchi, Benkherouf, Mekadem, Oualli, Keirsbulck and Labraga2013) for pitching motion.
Table 1 shows the mesh and time-step independence test results as well as the validation of the numerical set-up. Spatial independence was achieved by increasing the number of cells from 1 × 10⁵ to 4 × 10⁵. Indeed, this test was started from the independence test done for a sinusoidal oscillating foil (Alam & Muhammad Reference Alam and Muhammad2020). The temporal independence was achieved by changing the time step Δt from T/1000 to T/4000. The results are compared with the water tunnel experiments of Van Buren et al. (Reference Van Buren, Floryan, Wei and Smits2018), and the maximum percentage difference between the simulation and experiment is less than 5 %. The mesh with 2 × 10⁵ cells and Δt = T/2000 is found to be adequate for the prediction of thrust with reasonable accuracy. Further increase in mesh size or time-step greatly increases the simulation time, thus outweighing the solution accuracy. We, therefore, chose the mesh with 2 × 10⁵ cells and Δt = T/2000 for further simulations. Figure 4(b) shows a comparison of the present  ${\bar{C}_T}$ with the experimental results of Van Buren et al. (Reference Van Buren, Floryan, Wei and Smits2018). As expected, the 2-D simulation over predicts the
 ${\bar{C}_T}$, owing to the reasons including but not limited to the absence of the third dimension and the end effects caused by the finite span wing. Overall, the trend of the results matches quite well with the experimental results.
Grid and time independence test results (Std = 0.75, A* = 2.44 and  $\mathrm{\mathbb{T}} = 1.00$).

3. Results and discussion
Here, we present the results and discussion of  ${C_T}$,
 ${C_P}$, wake and connection between
 ${C_T}$,
 ${C_P}$, wake and cycle-averaged quantities (
 ${\bar{C}_T}$,
 ${\bar{C}_P}$, η). First, a general overview is provided for the variations in
 ${C_T}$ and
 ${C_P}$ with
 $\mathrm{\mathbb{T}}$, followed by deeper discussion of the same for some selected
 $\mathrm{\mathbb{T}}$ values and their connections with the wake. Then, some interesting cases of
 ${C_P}$ and
 ${C_T}$ at equilibrium and extreme positions with different
 $\mathrm{\mathbb{T}}$ are discussed. Finally,
 ${\bar{C}_T}$,
 ${\bar{C}_P}$ and η are discussed for the whole spectrum, including the dependence of the wake structure on
 $\mathrm{\mathbb{T}}$. Finally, we discuss the wake structures, wake width, averaged wake velocity profiles and the wake deflection. The effect of inertia on non-elastic energy storage systems is discussed in § 3.4. The rest of the sections discuss the elastic energy storage systems, where the effect of inertia is non-existent.
3.1. Instantaneous thrust, power and lift
Figure 5(a–j) shows  ${C_T}$ (red line) and
 ${C_P}$ (blue line) distributions in a complete oscillation cycle for
 $\mathrm{\mathbb{T}} = 0.80$, 0.85, 0.90, 0.95, 1.00, 1.05, 1.11, 1.15, 1.20 and 1.40. The corresponding phase portrait
 $\dot{\theta }^{\prime}- \theta ^{\prime}$ (black lines) is superimposed on the
 ${C_T}$ and
 ${C_P}$ lines. The
 ${C_T}$ lines laying outside (solid line) and inside (dashed line) of the phase portrait indicate positive and negative values of
 ${C_T}$, respectively. The same sign convention is applied to
 ${C_P}$ lines. This figure also facilitates a comparison of the results between modified motion
 $(\mathrm{\mathbb{T}} \ne 1.00)$ and sinusoidal motion (
 $\mathrm{\mathbb{T}} = 1.00$, figure 5e). Here, we will discuss the aerodynamics only for phase ϕ = 0°–180° (the upper half) as each profile has rotational symmetry of order two. Recall that the first and second quadrants of the phase portrait complement the faster and slower strokes, respectively, for
 $\mathrm{\mathbb{T}} < 1.00$ (figure 5a–d) while the strokes swap their quadrants for
 $\mathrm{\mathbb{T}} > 1.00$ (figure 5f–j).
Instantaneous thrust (red line) and power (blue line) coefficients in the phase plane for modified sine motion with time period ratio 0.80, 0.85, …, 1.20 and 1.40 in (a), (b), …, (j), respectively. Positive values of both coefficients (solid lines) are outward (outside of the phase portrait) and negative values (dashed lines) are inward. Power coefficient is scaled down eight times the thrust coefficient. Here, StA = 0.38.

When  $\mathrm{\mathbb{T}} < 1.00$, three distinct features can be noticed in the
 ${C_T}$ and
 ${C_P}$ distributions. First, the magnitudes of maximum and minimum
 ${C_T}$ increase when
 $\mathrm{\mathbb{T}}$ is decreased from 1.00 to 0.80. The same happens for
 ${C_P}$. For example, with
 $\mathrm{\mathbb{T}}$ decreases from 1.00 to 0.80, the maximum
 ${C_T}$ and
 ${C_P}$ values are enhanced by 41 % and 65 %, respectively. Second, the occurrence of the maximum
 ${C_T}$ shifts from the retract stroke at
 $\mathrm{\mathbb{T}} = 1.00$ to the forward (faster) stroke when
 $\mathrm{\mathbb{T}}$ is decreased from 1.00. Specifically, the maximum
 ${C_T}$ for
 $\mathrm{\mathbb{T}} = 0.80$ is at ϕ = 62°, laying in the forward stroke (figure 5a), while that for
 $\mathrm{\mathbb{T}} = 1.00$ is at ϕ = 107°, early in the retract stroke (figure 5e). Third, the peak
 ${C_P}$ position postpones with decreasing
 $\mathrm{\mathbb{T}}$, laying at ϕ = 156° (late in the retract stroke) for
 $\mathrm{\mathbb{T}} = 1.00$ and at ϕ = 194° (early in the next forward stroke) for
 $\mathrm{\mathbb{T}} = 0.80$. That is, the relationship between the peak
 ${C_P}$ position and
 $\mathrm{\mathbb{T}}$ value is opposite to that between the peak
 ${C_T}$ position and
 $\mathrm{\mathbb{T}}$ value. As such, the
 ${C_T}$ and
 ${C_P}$ peaks occurring in the second quadrant for
 $\mathrm{\mathbb{T}} = 1.00$ move away from each other when
 $\mathrm{\mathbb{T}}$ is decreased to 0.80. Moreover, the positions of
 ${C_P} = 0$ and
 ${C_T} = 0$ (transition from drag to thrust) appear at ϕ = 33°–36° and 37°–52° (depending on
 $\mathrm{\mathbb{T}}$), respectively, both slightly decreasing with decreasing
 $\mathrm{\mathbb{T}}$. Alam & Muhammad (Reference Alam and Muhammad2020) found that
 ${C_T}$ and
 ${C_P}$ are maximum at ϕ ≈ 112° and 157° for
 $\mathrm{\mathbb{T}} = 1.00$ with StA = 0.24–0.53, which are consistent with the present results.
When  $\mathrm{\mathbb{T}}$ is increased from 1.00 to 1.40 (figure 5e–j): (i) magnitudes of maximum
 ${C_T}$ and
 ${C_P}$ grow by approximately 150 % and 145 %, respectively, between
 $\mathrm{\mathbb{T}} = 1.00$ and 1.20, and by 990 % and 1770 %, respectively, between
 $\mathrm{\mathbb{T}} = 1.00$ and 1.40; (ii) magnitudes of minimum
 ${C_T}$ and
 ${C_P}$ diminish between
 $\mathrm{\mathbb{T}} = 1.00$ and 1.20, and enhance for
 $\mathrm{\mathbb{T}} = 1.40$ as compared to
 $\mathrm{\mathbb{T}} = 1.00$; (iii) the instantaneous transition from drag to thrust (i.e.
 ${C_T} = 0$) moves towards ϕ = 90° (extreme position); (iv) position of maximum
 ${C_T}$ moves toward the nearest equilibrium position (ϕ = 0° and 180°) and (v) the gap between the
 ${C_T}$ and
 ${C_P}$ peaks in the retract stroke shrinks. The
 ${C_P}$ diminishes in the forward stroke (ϕ = 0°–90°) with an increase in
 $\mathrm{\mathbb{T}}$, whereas grows in the retract stroke (ϕ = 90°–180°). That is, faster stroke will result in a higher
 ${C_P}$ and vice versa.
Overall, the above findings suggest that maximum  ${C_T}$ and
 ${C_P}$ prevail in the faster stroke (i.e. forward stroke for
 $\mathrm{\mathbb{T}} < 1.00$ and retract stroke for
 $\mathrm{\mathbb{T}} > 1.00$). Although maximum
 ${C_T}$ and maximum
 ${C_P}$ both rise when
 $\mathrm{\mathbb{T}}$ is increased or decreased from 1.00, the rise in the maximum
 ${C_P}$ is higher for
 $\mathrm{\mathbb{T}} > 1.00$ than for
 $\mathrm{\mathbb{T}} < 1.00$, as is that in the maximum
 ${C_T}$. However, for
 $1.00 < \mathrm{\mathbb{T}} \le 1.20$, the degree of the increase in
 ${C_T}$ is greater than that in
 ${C_P}$ and hence a higher efficiency may occur for
 $1.00 < \mathrm{\mathbb{T}} \le 1.20$ than for
 $\mathrm{\mathbb{T}} < 1.00$. The above observations raise a few questions. For example, which
 $\mathrm{\mathbb{T}}$ is beneficial? What are their implications on swimming motion? How does the efficiency vary with
 $\mathrm{\mathbb{T}}$?
3.1.1. Correspondence between  ${C_P}$ and ${C_T}$


Swimming based on  ${C_T}$ and
 ${C_P}$ can be broadly categorized into four scenarios: (I) spend energy and swim upstream, i.e.
 ${C_P} > 0$ and
 ${C_T} > 0$ (normal swimming); (II) spend energy, yet drift downstream, i.e.
 ${C_P} > 0$ and
 ${C_T} < 0$ (undesirable); (III) gain energy from the fluid and drift downstream, i.e.
 ${C_P} < 0$ and
 ${C_T} < 0$ (floating); and (IV) gain energy from the fluid and swim upstream, i.e.
 ${C_P} < 0$ and
 ${C_T} > 0$ (ideal). These scenarios essentially correspond to the four quadrants of the instantaneous thrust verus power plot (
 ${C_{Pi}}$ and
 ${C_{Pf}}$) as shown in figure 6(a), where quadrant II is undesirable and quadrant IV is ideal. The
 ${C_{Pi}}$ (dashed red line) and
 ${C_{Pf}}$ (green line) plots are provided only for the first half (ϕ = 0°–180°) of the oscillation as the plots for the second half of the oscillation overlap with those for the first half, while this is not the case for
 ${C_L}$. The overlapping arises from their (
 ${C_{Pi}}$ and
 ${C_{Pf}}$) generation mechanism, the product of the two waves, i.e.
 ${C_{Pi}} \propto \ddot{\theta }\dot{\theta }$ and
 ${C_{Pf}} \propto {M_z}\dot{\theta }$. The pressure difference between the upper and lower surfaces of the foil can readily be understood from the instantaneous lift coefficient
 $({C_L})$ (figure 6b). A positive
 ${C_L}$ means pressure is higher on the lower surface than on the upper surface, which produces a positive (counterclockwise) moment (see figure 2b). The maximum pitching angle is small, θmax ≪ 1, and hence the trend of the pressure difference between the upper and lower surfaces can be reasonably predicted by the trend of
 ${C_L}$. Hereinafter,
 ${C_L}$ will be understood as an alibi for the pressure difference, unless explicitly stated otherwise.
Sinusoidal pitching foil at  $\mathrm{\mathbb{T}} = 1.00$, variation of instantaneous (a) power coefficients (Cpi, owing to inertia and CPf, owing to fluid) with thrust coefficient and (b) lift coefficient with normalized angular position. (c–f) The wake structure for four phases namely (0°, 45°, 90° and 135°, respectively) are shown with
 $\varOmega _z^\ast ( = {\varOmega _z}d/{U_\infty }) = [ - 5,5]$, with red colour for +ve values and blue for negative. Here, StA = 0.38.

There are many studies on sinusoidal  $(\mathrm{\mathbb{T}} = 1.00)$ pitching foil. We therefore briefly iterate some important information from the literature for a comparison purpose. For
 $\mathrm{\mathbb{T}} = 1.00$, the foil at ϕ = 0° has negative
 ${C_T}$ and negative
 ${C_L}$ (figure 6a,b). The upper and lower surfaces act as pressure and suction surfaces, respectively, producing −Mz. As
 $\dot{\theta }$ is positive and maximum at ϕ = 0°,
 ${C_{Pf}}$ is positive but not maximum as −Mz is not necessarily maximum at ϕ = 0° but slightly before this (figure 6b). At this foil position, the resultant pressure force on the side surfaces largely contributes to the lift and negligibly to the thrust because the foil appears streamlined, having a minimum projection on the y-axis and a maximum projection on the x-axis. The pressure on the semicircular leading edge and viscous force are largely responsible for the generation of the negative thrust (Alam & Muhammad Reference Alam and Muhammad2020). As the foil moves away from the equilibrium position, the upper shear-layer separating from the foil tip continues to roll-up (figure 6c). When the foil reaches ϕ = 45°, the pressure difference across its upper and lower surfaces becomes zero (see
 ${C_L} = 0$ at ϕ = 45° in figure 6b). That is, the pressure on the upper surface decreases and/or that on the lower surface increases as ϕ increases from 0° to 45°. The
 ${C_T}$ at ϕ = 45° is higher than that at ϕ = 0°, albeit still negative. From ϕ = 0° to 45°, the magnitudes of both
 $\dot{\theta }$ and Mz decline, which leads to a decreased
 ${C_{Pf}}$. When the foil moves from ϕ = 45° to 90°,
 ${C_L}$ increases with ϕ (figure 6b), which suggests that the pressure on the upper surface is progressively smaller than that on the lower surface. This pressure difference contributing to the thrust makes
 ${C_T}$ increasingly positive (figure 6a). For the same reason, Mz is positive. From ϕ = 45° to 90°, as Mz grows and
 $\dot{\theta }$ declines,
 ${C_{Pf}}$ becomes minimum between ϕ = 45° and 90°. That is, in the second half of the forward stroke (ϕ = 45°–90°), the foil can move forward, gaining energy from the fluid (negative power input). In the forward stroke (ϕ = 0°–90°), inertia being negative
 $({C_{Pi}} < 0)$ also supports the motion. From ϕ = 0° to 90°, the increase in
 ${C_L}$ is accompanied by vortex growth and shedding from the upper side (figure 6c–e). At ϕ = 90°–135° where the foil is in the retract stroke (
 $\theta^{\prime}$ decreasing),
 ${C_L}$ keeps increasing and
 ${C_T}$ becoming maximum at ϕ = 107° declines with a further increase in ϕ while
 ${C_{Pf}}$ is positive, growing with increasing ϕ. Meanwhile, the shear layer on the lower surface starts to roll-up to form a counterclockwise vortex (red colour) behind the foil tip (figure 6f). From ϕ = 135° to 180°, both
 ${C_L}$ and
 ${C_T}$ drop while
 ${C_{Pf}}$ reaches a maximum at ϕ = 158°. The
 ${C_{Pi}}$ is positive during retract strokes, being maximum at ϕ = 135°.
Now we will discuss the case with  $\mathrm{\mathbb{T}} = 1.20$ (figure 5i), where the increase in the maximum
 ${C_T}$ is larger than that in the maximum
 ${C_P}$, as compared to the case with
 $\mathrm{\mathbb{T}} = 1.00$ (figure 5e). Figure 7 shows
 ${C_{Pf}}$,
 ${C_{Pi}}$ versus
 ${C_T}$, and
 ${C_L}$ versus
 $\theta^{\prime}$. At ϕ = 0°–45°,
 ${C_L}$ increases slowly, i.e. the pressure difference between the upper and lower surfaces of the foil does not change much, as do not
 ${C_{Pf}}$ and
 ${C_T}$ (figure 7a,b). The
 ${C_{Pi}}$ magnitude increases negligibly, albeit negative. The
 ${C_T}$ nevertheless rapidly enhances between ϕ = 45° and 90° while
 ${C_{Pf}}$ is negative and small in magnitude. At ϕ = 90°, both
 ${C_{Pf}}$ and
 ${C_{Pi}}$ become zero. It is worth pointing out that because the forward stroke for
 $\mathrm{\mathbb{T}} = 1.20$ has a longer period than the retract stroke (figure 3a), the foil motion in the forward stroke (ϕ = 0°–90°) is relatively slow, requiring less
 ${C_{Pi}}$ and
 ${C_{Pf}}$ than that for
 $\mathrm{\mathbb{T}} = 1.00$ (figures 6a and 7a). Moreover, the switchover in the direction of the pressure difference is delayed as compared with that for
 $\mathrm{\mathbb{T}} = 1.00$, occurring at ϕ = 45° and 68° for
 $\mathrm{\mathbb{T}} = 1.00$ and 1.20, respectively. The foil switches to the shorter period in the retract stroke (ϕ = 90°–180°) and experiences higher
 $\dot{\theta }$ and
 $\ddot{\theta }$ magnitudes than in the forward stroke. The
 ${C_L}$ and
 ${C_{Pf}}$ both thus flare up from ϕ = 90° to 135°, yielding a maximum
 ${C_T}$ at ϕ = 123° (figure 5i). From ϕ = 135° to 180°,
 ${C_L}$ rapidly drops; as do
 ${C_T}$ and
 ${C_{Pf}}$. The
 ${C_{Pf}}$, however, reaches a peak at ϕ = 140° as the magnitude of
 $\dot{\theta }$ (−ve) increases and
 ${C_L}$ (+ve) decreases between ϕ = 135° and 180°. At ϕ = 180°, the
 ${C_{Pf}}$ for
 $\mathrm{\mathbb{T}} = 1.20$ is much smaller than that for
 $\mathrm{\mathbb{T}} = 1.00$ (figures 7a and 6a), because of lower
 ${C_L}$ (hence Mz) produced for
 $\mathrm{\mathbb{T}} = 1.20$.
For  $\mathrm{\mathbb{T}} = 1.20$, variation of instantaneous (a) power coefficients (Cpi, owing to inertia and CPf, owing to fluid) with thrust coefficient and (b) lift coefficient with normalized angular position. Here, StA = 0.38.

Figure 8 shows  ${C_{Pf}}$,
 ${C_{Pi}}$ versus
 ${C_T}$, and
 ${C_L}$ versus
 $\theta^{\prime}$ for
 $\mathrm{\mathbb{T}} = 0.80$, which is the lowest
 $\mathrm{\mathbb{T}}$ studied. At the equilibrium position (ϕ = 0°),
 ${C_T}$ does not change appreciably between
 $\mathrm{\mathbb{T}} = 0.80$, 1.00 and 1.20 (figures 6–8), which indicates that
 ${C_T}$ at equilibrium position is not predominantly influenced by
 $\mathrm{\mathbb{T}}$ as it mainly arises from the pressure on the head of the foil and the viscous forces. The
 ${C_L}$ magnitude at equilibrium position for
 $\mathrm{\mathbb{T}} = 0.80$ is, however, quite high compared with that for the
 $\mathrm{\mathbb{T}} = 1.00$ and 1.20 (see figures 6a and 7a) cases, which results in a much higher
 ${C_{Pf}}$ for
 $\mathrm{\mathbb{T}} = 0.80$ (figure 8a). The forward stroke for
 $\mathrm{\mathbb{T}} = 0.80$ is the fast quarter, where
 $\dot{\theta }^{\prime}$ first increases and then decreases, reaching a maximum value at ϕ = 25° (see phase portrait in figure 5a or figure 3b). This increase and decrease in
 $\dot{\theta }^{\prime}$ are reciprocated by
 ${C_L}$ variations (figure 8b). There is a decrease in
 ${C_T}$ and an increase in
 ${C_{Pf}}$ immediately after the start of the forward stroke, which is followed by a large increase in
 ${C_T}$ and a large decrease in
 ${C_{Pf}}$ up to the mid (ϕ = 45°) of the forward stroke. The
 ${C_{Pf}}$ reaches its maximum at ϕ = 15°. The change in the
 ${C_L}$ sign happens at ϕ = 35° and that for
 ${C_{Pf}}$ takes place at ϕ = 34°. At ϕ = 45°–90°, the increase and decrease in
 ${C_L}$ with ϕ are accompanied by the same in
 ${C_T}$. The local maxima of
 ${C_L}$ occur at ϕ = 60°, which is followed by
 ${C_T}$ becoming maximum at ϕ = 62°. In the retract (slower) stroke,
 ${C_T}$ declines, but
 ${C_{Pf}}$ and
 ${C_L}$ increase. The general feature for
 $\mathrm{\mathbb{T}} \ne 1.00$ is that a higher
 ${C_P}$ (both
 ${C_{Pf}}$ and
 ${C_{Pi}}$) is required to make a stroke faster. It is understood from figure 6a that, on average, a higher
 ${C_{Pf}}$ is required in the retract stroke than in the forward stroke for
 $\mathrm{\mathbb{T}} = 1.00$. As an additional
 ${C_P}$ is required to make a stroke faster,
 ${C_P}$ grows more rapidly in the retract stroke for
 $\mathrm{\mathbb{T}} > 1.00$ (figure 5f–j) and in the forward stroke for
 $\mathrm{\mathbb{T}} < 1.00$ (figure 5a–d).
For  $\mathrm{\mathbb{T}} = 0.80$, variation of instantaneous (a) power coefficients (Cpi, owing to inertia and CPf, owing to fluid) with thrust coefficient and (b) lift coefficient with normalized angular position. Here, StA = 0.38.

At ϕ = 0°, the foil is streamlined, and both viscous force and pressure force on the foil head contribute to  ${C_T}$ that is almost independent of
 $\mathrm{\mathbb{T}}$ (figures 6a–8a). However, the
 ${C_{Pf}}$ plays an important role in
 ${C_L}$ generation at ϕ = 0°. The
 $\dot{\theta }$ at ϕ = 0° is the same for all
 $\mathrm{\mathbb{T}}$ (see the slopes of curves in figure 3a, this is not clear in figure 3b, owing to
 ${\dot{\theta }_{max}}$ being different for each
 $\mathrm{\mathbb{T}}$) and hence the variation in
 ${C_L}$ with
 $\mathrm{\mathbb{T}}$ solely arises from the change in
 ${C_{Pf}}$ (figures 6b–8b). At ϕ = 90°,
 $\dot{\theta } = 0$ and hence
 ${C_{Pf}} = {C_{Pi}} = 0$, the
 ${C_L}$ at extreme position is supposed to be dependent on
 $\mathrm{\mathbb{T}}$, but it is not;
 ${C_L}$ increases from 28.0 to 29.8 (0.6 %) between
 $\mathrm{\mathbb{T}} = 0.80$ and 1.20, and reduces to 29.5 at
 $\mathrm{\mathbb{T}} = 1.40$ (not shown).
Figure 9 shows the regimes of swimming for  $\mathrm{\mathbb{T}} = 0.80$, 1.00, 1.20 and 1.40 in one oscillation period. Each regime is presented in a shade of a particular colour to distinguish regimes. The shade of the same colour distinguishes the magnitude of
 ${C_T}$, with dull and bright shades representing low and high magnitudes of
 ${C_T}$, respectively. A comparison of figures 9(a) and 9(b) reflects that speeding up the forward stroke (i.e.
 $\mathrm{\mathbb{T}} < 1.00$) does not appreciably affect the undesirable regime (II, orange), ϕ = −20–33° and −18–35° for
 $\mathrm{\mathbb{T}} = 0.80$ and 1.00, respectively, laying around the equilibrium. The magnitude of
 ${C_T}$ is however increased
 $({C_T} < 0)$, with drag increasing. Nestling close to the middle of the forward stroke, floating regime (III, grey) shrinks from spanning 17° to 4° when
 $\mathrm{\mathbb{T}}$ is decreased from 1.00 to 0.80. The ideal regime (IV, yellow) dramatically stretches from spanning 38°
 $(\mathrm{\mathbb{T}} = 1.00)$ to 53°
 $(\mathrm{\mathbb{T}} = 0.80)$, occupying the end of the forward stroke. The
 ${C_T}$ in the ideal regime is also enhanced owing to the increased speed of the forward stroke (i.e.
 $\mathrm{\mathbb{T}} < 1.00$). The normal swimming regime (I, blue) covers most of the retract stroke, approximately 70° for
 $\mathrm{\mathbb{T}} = 0.80$ and 72° for
 $\mathrm{\mathbb{T}} = 1.00$, while the rest of retract stroke is the undesirable regime. Regimes I (normal swimming) and IV (undesirable) do not change much between
 $\mathrm{\mathbb{T}} = 0.80$ and 1.00; the magnitude of
 ${C_T}$ however decreases in the normal swimming regime (when
 $\mathrm{\mathbb{T}} < 1.00$), as compared to
 $\mathrm{\mathbb{T}} = 1.00$ (figure 9a,b).
Regimes of swimming for (a)  $\mathrm{\mathbb{T}} = 0.80$, (b)
 $\mathrm{\mathbb{T}} = 1.00$, (c)
 $\mathrm{\mathbb{T}} = 1.20$ and (d)
 $\mathrm{\mathbb{T}} = 1.40$ for StA = 0.38. The blue, yellow, grey and orange colours represent the regimes I, II, III and IV, respectively. The shades of each colour represent the magnitude of CT.

The slowing down of the forward stroke (i.e.  $\mathrm{\mathbb{T}} > 1.00$), as expected, stretches undesirable (IV) and floating (III) regimes to a span of 75° and 22°, respectively, at
 $\mathrm{\mathbb{T}} = 1.20$ from a span of 53° and 17° at
 $\mathrm{\mathbb{T}} = 1.00$. The magnitude of
 ${C_T}$ (in forward stroke) also decreases for
 $\mathrm{\mathbb{T}} > 1.00$ as compared to
 $\mathrm{\mathbb{T}} = 1.00$ (
 ${C_T} < 0$, decreased drag). Ideal regime (II) contracts from a span of 38° at
 $\mathrm{\mathbb{T}} = 1.00$ to 17° at
 $\mathrm{\mathbb{T}} = 1.20$, with
 ${C_T}$ also decreasing (figure 9b,c). In the faster retract stroke
 $(\mathrm{\mathbb{T}} > 1.00)$, the span of normal swimming regime (I) diminishes from 72° at
 $\mathrm{\mathbb{T}} = 1.00$ to 66° at
 $\mathrm{\mathbb{T}} = 1.20$, but the maximum
 ${C_T}$ is enhanced twofold. As such, undesirable regime (IV) expands from
 $\mathrm{\mathbb{T}} = 1.00$ to 1.20, laying mostly in the forward stroke (figure 9b,c).
The pattern modifies significantly when the forward stroke is further slowed down to the case of  $\mathrm{\mathbb{T}} = 1.40$, where the floating regime (III) nestling around the equilibrium position now spans most of the forward stroke i.e. from −30° to 50° (figure 9d). The undesirable regime (IV) shrinks and shifts further towards the end of the forward stroke, spanning 50°–77°. One more floating regime (III) and ideal regime (II) are observed at the end of the forward stroke, both being very narrow. The normal swimming regime (I) further shrinks from 66° for
 $\mathrm{\mathbb{T}} = 1.20$ to 59° for
 $\mathrm{\mathbb{T}} = 1.40$, followed by an infinitesimal undesirable (IV) regime spanning only 2°. The floating regime (III) covers the rest of the retract stroke and expands much further into the next forward stroke. The magnitude of
 ${C_T}$ is much larger for
 $\mathrm{\mathbb{T}} = 1.40$ than for
 $0.80 \le \mathrm{\mathbb{T}} \le 1.20$. Hence, figure 9(d) uses a scale four times the scale for figure 9(a–c).
The following points can be distilled from the above discussion. The undesirable and ideal modes are fashionably opposite to each other; the former provides power but obtains no net thrust while the latter receives both power and thrust. The forward stroke (ϕ = 0° to 90°) for  $\mathrm{\mathbb{T}} = 1.00$ generally envelops undesirable and ideal regimes separated by a narrow floating regime, while the retract stroke largely provides normal swimming (figure 9b). When
 $\mathrm{\mathbb{T}}$ is increased from 0.80 to 1.20, the spans of the undesirable and floating regime (both involving
 ${C_T} < 0$) in the forward stroke dramatically grow and that of the ideal regime (involving
 ${C_T} > 0$) contracts. That is, the corresponding change in the forward stroke essentially degrades thrust. However, with
 $\mathrm{\mathbb{T}}$ increasing from 0.80 to 1.20, the spans of regimes I
 $({C_T} > 0)$ and II
 $({C_T} < 0)$ in the retract stroke do not change much (figure 9), but the magnitude of thrust is radically enhanced in regime I (see figure 5 or figure 9), which is the main reason for enhancement of the time-averaged thrust at
 $\mathrm{\mathbb{T}} = 1.20$. The two scenarios (decreasing and increasing thrust in the forward and retract strokes with increasing
 $\mathrm{\mathbb{T}}$) further point to the occurrence of the minimum
 ${\bar{C}_T}$ between
 $\mathrm{\mathbb{T}} = 0.80$ and 1.20. For
 $\mathrm{\mathbb{T}} = 1.40$,
 ${C_T} < 0$ in regimes III and IV of the forward stroke further degrades when compared with that for
 $\mathrm{\mathbb{T}} = 1.20$. The retract stroke for
 $\mathrm{\mathbb{T}} = 1.40$, unlike the same for
 $\mathrm{\mathbb{T}} = 1.20$, has a floating regime
 $({C_T} < 0)$. The
 ${C_T}$ in the normal swimming regime is very large, which makes the
 ${\bar{C}_T}$ large for
 $\mathrm{\mathbb{T}} = 1.40$.
Figure 10 shows the individual contributions  ${\bar{C}_{TF}}$ and
 ${\bar{C}_{TR}}$ of the forward and retract strokes, respectively, to
 ${\bar{C}_T}$ for StA = 0.38, where
 ${\bar{C}_{TF}}$ and
 ${\bar{C}_{TR}}$ are the thrust force coefficients integrated over the forward and retract strokes of a complete oscillation cycle, respectively, i.e.
 \begin{align}{\bar{C}_{TF}} = \frac{2}{{\rm \pi} }\left[ {\int_0^{{\rm \pi} /2} {{C_T}\,\textrm{d}\phi } + \int_{\rm \pi} ^{3{\rm \pi} /2} {{C_T}\,\textrm{d}\phi } } \right]\quad \textrm{and}\quad {\bar{C}_{TR}} = \frac{2}{{\rm \pi} }\left[ {\int_{{\rm \pi} /2}^{\rm \pi} {{C_T}\,\textrm{d}\phi } + \int_{3{\rm \pi} /2}^{2{\rm \pi} } {{C_T}\,\textrm{d}\phi } } \right].\end{align}
As discussed above, the  ${\bar{C}_{TF}}$ and
 ${\bar{C}_{TR}}$ contributions to
 ${\bar{C}_T}$ decrease and increase, respectively, when
 $\mathrm{\mathbb{T}}$ is increased. The magnitude of increase with
 $\mathrm{\mathbb{T}}$ is however greater than that of the decrease, which explains why
 ${\bar{C}_T}$ grows with
 $\mathrm{\mathbb{T}}$. The figure also indicates that
 ${\bar{C}_T}$ would be a minimum at
 $\mathrm{\mathbb{T}} = 0.83$.
Strokewise averaged thrust dependence on  $\mathrm{\mathbb{T}}$ for StA = 0.38.

There are four general locomotion behaviours for swimming fish observed in nature: steady swimming, kick and glide (intermittent swimming), fast start (including C-start and S-start) and braking (e.g. Jayne, Lozada & Lauder Reference Jayne, Lozada and Lauder1996; Shadwick & Lauder Reference Shadwick and Lauder2006). The overview of figure 9 echoes some interesting observations in natural biological swimming. First, for a fast start that is typically associated with the escape response of a fish, high power is required to hastily bend the fish body to its limit, and the thrust should be generated in-phase with the body movement (power). This is the case for  $\mathrm{\mathbb{T}} > 1.00$ (figure 9c,d), where
 ${C_T}$ and
 ${C_P}$ are almost in-phase and thrust is generated near the extreme position of the foil (figure 5f–j). In addition, the fast-start response depending on the fish body curvature and the escape route is characterized as C-start (fish escapes from its wake) or S-start (fish escapes side-ways). This is achieved by high lateral forces or moments achieved when the foil tail is near its extreme position (
 $\mathrm{\mathbb{T}} > 1.00$, see figure 7b showing high
 ${C_L}$ near the extreme position). Second, for steady swimming, the steady motion of the foil tail guarantees the impulse of thrust that sustains steady swimming, just as in the case of
 $\mathrm{\mathbb{T}} = 1.00$ (figure 9b). Third, for braking, the drag should be achieved near the equilibrium position which is the case for
 $\mathrm{\mathbb{T}} = 0.80$, where
 ${C_T} < 0$, i.e. undesirable regime concentrated near the equilibrium position (figure 9a). Also, the fact that for
 $\mathrm{\mathbb{T}} = 0.80$, the maximum drag is generated when the most power is applied (i.e.
 ${C_T}$ and
 ${C_P}$ are out of phase, see figure 5a) further shows the similarity of
 $\mathrm{\mathbb{T}} < 1.00$ motion to the braking phenomenon.
3.2. Effects of θ′, $\dot{\theta }^{\prime}$ and $\ddot{\theta }^{\prime}$ on instantaneous thrust, power and lift


Figure 11 shows the contour plots of instantaneous thrust, power and lift on the  $\mathrm{\mathbb{T}}- t^{\prime}$ plane for StA = 0.38, overlaid with solid, dashed and dash-dotted lines representing extremes of θ′,
 $\dot{\theta }^{\prime}$ and
 $\ddot{\theta }^{\prime}$ (
 $= \ddot{\theta }/{\ddot{\theta }_{max}}$, where
 ${\ddot{\theta }_{max}}$ is the maximum angular acceleration, rads−2), respectively, with maximum and minimum values represented by green and black lines, respectively. Here, the subscripts ‘max’ and ‘min’ denote maximum and minimum, respectively. The dotted line marks the half time-period (end of the retract stroke), while the extremes of θ′ mark the ends of the forward strokes. The contours are coloured such that shades of red and blue represent positive and negative values of the contour variable. When
 $\mathrm{\mathbb{T}} < 1.00$, the extremes (positive and negative) of
 $\dot{\theta }^{\prime}$ and
 $\ddot{\theta }^{\prime}$ shift from the stroke boundaries (θ′ = 0 and
 $\theta ^{\prime} = {\theta ^{\prime}_{max}}$) to the fast forward stroke (figure 11). In contrast, when
 $\mathrm{\mathbb{T}} > 1.00$, the extremes of
 $\dot{\theta }^{\prime}$ and
 $\ddot{\theta }^{\prime}$ fall in the fast retract stroke.
Effect of instantaneous  $\theta ^{\prime},\dot{\theta }^{\prime},\;\; \textrm{and},\;\ddot{\theta }^{\prime}$ on (a) CT, (b) CPf, (c) CPi and (d) CL for StA = 0.38. The straight, dashed and dash–dotted lines represent extremes of
 $\theta ^{\prime}$,
 $\dot{\theta }^{\prime}$ and
 $\ddot{\theta }^{\prime}$, with green and black colours of lines for maximum and minimum values. FS and RS stands for Forward and Retract Stroke, respectively.

The  ${C_T}$ for
 $\mathrm{\mathbb{T}} = 1.00$ is minimum in the forward stroke at t′ ≈ 0.062 (ϕ ≈
 ${\rm \pi}$/8) and maximum in the retract stroke t′ ≈ 0.31 (ϕ ≈ 5
 ${\rm \pi}$/8) (figure 5e), see also Alam & Muhammad (Reference Alam and Muhammad2020). With
 $\mathrm{\mathbb{T}}$ decreasing from 1.00,
 ${C_T}$ remains minimum at t′ ≈ 0.062 while the maximum
 ${C_T}$ gradually shifts from the retract stroke to the preceding forward stroke, as does
 ${\ddot{\theta }^{\prime}_{min}}$. The reason for the occurrence of the maximum
 ${C_T}$ following
 ${\ddot{\theta }^{\prime}_{min}}$ is the fluid inertia lagging the foil inertia, which generates a large pressure difference between the two surfaces of the foil (Alam & Muhammad Reference Alam and Muhammad2020). The relationship between fluid inertia, foil motion and fluid forces is detailed by Alam & Muhammad (Reference Alam and Muhammad2020). When
 $\mathrm{\mathbb{T}}$ is increased from 1.00, both
 ${\ddot{\theta }^{\prime}_{min}}$ and
 ${\dot{\theta }^{\prime}_{min}}$ come into being in the retract stroke, and the maximum
 ${C_T}$ lagging
 ${\ddot{\theta }^{\prime}_{min}}$ approaches
 ${\dot{\theta }^{\prime}_{min}}$ at
 $\mathrm{\mathbb{T}} = 1.40$ (figure 11a). Particularly for
 $1.30 \le \mathrm{\mathbb{T}} \le 1.40$, the
 $\dot{\theta }^{\prime}$ in the retract stroke is much higher (see the slope for
 $\mathrm{\mathbb{T}} = 1.40$ in figure 3a), which makes it difficult for the fluid inertia to keep up with the foil, resulting in a more time delay (t′) between
 ${\ddot{\theta }^{\prime}_{min}}$ and maximum
 ${C_T}$, compared with that for
 $1.00 < \mathrm{\mathbb{T}} < 1.30$.
The  ${C_{Pf}}$ at the start of the forward stroke is positive and negative for
 $0.80 \le \mathrm{\mathbb{T}} \le 1.30$ and
 $1.30 < \mathrm{\mathbb{T}} \le 1.40$, respectively (see also ϕ = 0° in figures 5j and 8a), linked to the motion state at the end of the earlier retract stroke, which will be discussed later. The
 ${C_{Pf}}$ for
 $\mathrm{\mathbb{T}} > 1.30$ is positive in the middle of the slow forward stroke, which results from the slow-motion foil pushing the fluid. The
 ${C_{Pf}}$ switches to negative before the end of the forward stroke (i.e. at
 $t^{\prime} \approx t^{\prime}({\theta ^{\prime}_{max}}) - 0.125$) because of the decelerating foil resisting the fluid inertia. The
 ${C_{Pf}}$ becomes zero at the boundary between the forward and retract strokes (see
 ${\dot{\theta }^{\prime}_{max}}$ line in figure 11b) as
 $\dot{\theta }^{\prime} = 0$ (see (2.9)). The region of the retract stroke largely consists of positive
 ${C_{Pf}}$, except for
 $1.30 < \mathrm{\mathbb{T}} \le 1.40$ in which the
 ${C_{Pf}}$ is negative beyond
 ${\dot{\theta }^{\prime}_{max}}$ (figure 11b). The change in the behaviour of
 ${C_{Pf}}$ with t′ in the retract stroke for
 $\mathrm{\mathbb{T}} > 1.30$ is attributed to the change in the foil acceleration from negative to positive at
 ${\dot{\theta }^{\prime}_{min}}$ at which the fluid (negatively accelerated before
 ${\dot{\theta }^{\prime}_{min}}$) bumps into the foil that moves at a slower pace than the fluid.
Being the product of  $\dot{\theta }^{\prime}$ and
 $\ddot{\theta }^{\prime}$ (2.9),
 ${C_{Pi}}$ is zero when one of them is zero, i.e. at
 $\dot{\theta }^{\prime} = 0$ (
 ${\theta ^{\prime}_{max}}$ and
 ${\theta ^{\prime}_{min}}$ lines) and at
 $\ddot{\theta }^{\prime} = 0$ (
 ${\dot{\theta }^{\prime}_{max}}$ and
 ${\dot{\theta }^{\prime}_{min}}$ lines). The
 ${C_{Pi}}$ for
 $\mathrm{\mathbb{T}} > 1.00$ is negative in the forward stroke because of the foil deceleration. However, for
 $\mathrm{\mathbb{T}} < 1.00$, the
 ${C_{Pi}}$ is initially positive before
 ${\dot{\theta }^{\prime}_{max}}$ and becomes negative after
 ${\dot{\theta }^{\prime}_{max}}$where
 $\dot{\theta }^{\prime}$ diminishes. The retract stroke is engulfed with positive
 ${C_{Pi}}$ as
 $\dot{\theta }^{\prime}$ increases in magnitude until
 ${\dot{\theta }^{\prime}_{min}}$ (figure 11c). For
 $\mathrm{\mathbb{T}} = 1.00$, the
 ${C_{Pi}}$ is negative and positive in the forward and retract strokes, respectively, dictated by negative and positive
 $\ddot{\theta }^{\prime}$ at the corresponding strokes. In constrast, for
 $\mathrm{\mathbb{T}} \ne 1.00$, the sign of
 ${C_{Pi}}$ is contingent on
 $\dot{\theta }^{\prime}$ and
 $\ddot{\theta }^{\prime}$ in the individual strokes, as explained above.
Because θmax ≪ 1, the  ${C_L}$ is directly linked to the difference in pressure between the upper and lower surfaces of the foil. Because the foil undergoes forced motion, the
 ${C_L}$ will typically acts opposite to the motion with some phase lag because of the fluid inertia (Alam & Muhammad Reference Alam and Muhammad2020). The
 ${C_L}$ is essentially positive (see figure 2b for sign convention) for most of the downward stroke including retract and forward strokes between
 ${\theta ^{\prime}_{max}}$ and
 ${\theta ^{\prime}_{min}}$, with
 ${C_L}$ lagging θ′ (see figure 11d). The
 ${C_L}$ largely follows the trend of
 ${C_{Pf}}$ variation with t′ in the retract stroke for
 $\mathrm{\mathbb{T}} > 1.30$, with
 ${C_L}$ becoming momentarily negative after
 ${\dot{\theta }^{\prime}_{min}}$. As expected, the amplitude of
 ${C_L}$ increases as the magnitude of
 $\dot{\theta }^{\prime}$ enhances, i.e. with the retract stroke getting shorter. The
 $\dot{\theta }^{\prime}$,
 $\dot{\theta }^{\prime}$ and
 $\ddot{\theta }^{\prime}$ all affect
 ${C_T}$,
 ${C_{Pf}}$,
 ${C_{Pi}}$ and
 ${C_L}$. The
 ${C_{Pi}}$ is influenced by
 $\dot{\theta }^{\prime}$ and
 $\ddot{\theta }^{\prime}$ only, following (2.9), whereas
 ${C_T}$,
 ${C_L}$ and
 ${C_{Pf}}$ all have a strong dependence on
 $\mathrm{\mathbb{T}}$.
3.3. Effect of $\mathrm{\mathbb{T}}$ on time-averaged thrust, power coefficient and efficiency

Very complex scenarios have been observed in the instantaneous  ${C_T}$ and
 ${C_P}$ when
 $\mathrm{\mathbb{T}}$ is increased or decreased from 1.00. It would be interesting to see the dependence of time-averaged hydrodynamic parameters on
 $\mathrm{\mathbb{T}}$. Figure 12 shows dependence of
 ${\bar{C}_T}$,
 ${\bar{C}_P}$ and η on
 $\mathrm{\mathbb{T}}$ for the three selected cases with StA = 0.23, 0.36 and 0.43 lying within the StA range of flying and swimming animals reported in the literature (see e.g. Triantafyllou, Triantafyllou & Grosenbaugh Reference Triantafyllou, Triantafyllou and Grosenbaugh1993; Taylor et al. Reference Taylor, Nudds and Thomas2003). At a given
 $\mathrm{\mathbb{T}}$,
 ${\bar{C}_T}$ escalates with increasing StA. With
 $\mathrm{\mathbb{T}}$ increasing from 0.80 to 1.40,
 ${\bar{C}_T}$ first declines and then grows, being minimum at
 $\mathrm{\mathbb{T}} = 0.85$ for all StA values (figure 12a). This however is not in conflict with the earlier finding (from figure 10), because the simulated
 $\mathrm{\mathbb{T}}$ value closest to 0.83 is 0.85 and hence we see minimum
 ${\bar{C}_T}$ occurring at
 $\mathrm{\mathbb{T}} = 0.85$. The border of the minimum
 ${\bar{C}_T}$ coincides with that separating 2P and 2S wakes, which will be discussed in the later sections. For sinusoidal motion,
 ${C_T}$ is large and small when the foil is close to the extreme and equilibrium, respectively (
 $\mathrm{\mathbb{T}} = 1.00$, figure 6a). As the
 $\mathrm{\mathbb{T}}$ is increased (say from 0.83 to 1.40), the increased contribution of the retract stroke to
 ${\bar{C}_T}$ is slightly higher than the decreased contribution of the forward stroke to
 ${\bar{C}_T}$ (figure 10). Hence the rate of increase in
 ${\bar{C}_T}$ with
 $\mathrm{\mathbb{T}}$ grows with increasing
 $\mathrm{\mathbb{T}}$ (figure 12a). The wider 2P wake forming for
 $\mathrm{\mathbb{T}} \le 0.85$ (shown later) results in
 ${\bar{C}_T}$ growing for
 $\mathrm{\mathbb{T}} \le 0.85$ (figure 12a). This can also be explained in terms of the shift of the
 ${C_T}$ peak toward the extreme position (figure 5a). When appearing near the extreme, the peak becomes broad because of the small velocity magnitude of the foil. When
 $\mathrm{\mathbb{T}}$ is increased from 0.85 to 0.95, the
 ${C_T}$ peak declines in height but shifts toward the extreme (ϕ = 90°) (figure 5). The effects of two scenarios cancel each other; the ensuing effect on
 ${\bar{C}_T}$ is thus very small between
 $\mathrm{\mathbb{T}} = 0.85$ and 0.95 (figure 12a). However, for
 $\mathrm{\mathbb{T}} = 0.95- 1.40$, although the
 ${C_T}$ peak moves away from the extreme, its height grows rapidly, such that the value of
 ${C_T}$ at ϕ = 90° does not change appreciably (figure 5). The
 ${\bar{C}_T}$ increase with the increase in
 $\mathrm{\mathbb{T}}$ is thus rapid for
 $\mathrm{\mathbb{T}} > 0.95$ (figure 12a).
Dependence on  $\mathrm{\mathbb{T}}$ of (a) thrust coefficient, (b) input power coefficient and (c) efficiency. To avoid the clutter, only three different StA values are plotted.

The  ${\bar{C}_P}$ follows the same trend except that it becomes a minimum at
 $\mathrm{\mathbb{T}} = 1.00$. Recalling figure 5, one can see that when
 $\mathrm{\mathbb{T}}$ is increased from 0.80 to 0.95, the
 ${C_P}$ peak occurring in the first quadrant moves away from the extreme, with the peak height diminishing. Both cause
 ${\bar{C}_P}$ to decline with
 $\mathrm{\mathbb{T}}$ (figure 12b). The scenario is opposite for
 $\mathrm{\mathbb{T}} > 1.00$, the peak budging toward the extreme with the peak height growing (figure 5). The
 ${\bar{C}_P}$ therefore grows, with a minimum
 ${\bar{C}_P}$ prevailing at
 $\mathrm{\mathbb{T}} = 1.00$ (figure 12). The η for StA = 0.36 increases monotonically with
 $\mathrm{\mathbb{T}}$ while that for StA = 0.43 does the same for
 $0.80 \le \mathrm{\mathbb{T}} \le 1.20$ but declines for
 $\mathrm{\mathbb{T}} > 1.2$ (figure 12c). The η decreases to a minimum at
 $\mathrm{\mathbb{T}} = 0.90$ for the drag cases (e.g. StA = 0.23 in figure 12c) then increases rapidly with increasing
 $\mathrm{\mathbb{T}}$. Interestingly, the drag–thrust boundary can be crossed at a smaller StA by changing the foil kinematics
 $\mathrm{\mathbb{T}}$ (figure 12a). Because we are not interested in drag-creating conditions, no further examination will be made for this.
Figures 13(a)–13(c) presents the full spectrum of  ${\bar{C}_T}$,
 ${\bar{C}_P}$ and η on the
 $\mathrm{\mathbb{T}}- S{t_A}$ plane. The solid line represents the drag-thrust boundary. The dependence of
 ${\bar{C}_T}$,
 ${\bar{C}_P}$ and η on StA at
 $\mathrm{\mathbb{T}} = 1.00$ is well known and also can be seen here, all increasing with StA. The increase is, however, sensitive to
 $\mathrm{\mathbb{T}}$. A greater increase in
 ${\bar{C}_T}$ and
 ${\bar{C}_P}$ with StA is observed when
 $\mathrm{\mathbb{T}}$ is increased from 1.00, shifting the drag–thrust boundary to a smaller StA. The same happens when
 $\mathrm{\mathbb{T}}$ is decreased from 1.00 but the increase in
 ${\bar{C}_T}$ is smaller than that for
 $\mathrm{\mathbb{T}} = 1.00$. As such, a significant enhancement in η is observed with increasing
 $\mathrm{\mathbb{T}}$ from 1.00 while the opposite is the case when
 $\mathrm{\mathbb{T}}$ is decreased from 1.00. For StA > 0.40, an increase in
 $\mathrm{\mathbb{T}} > 1.20$ leads to η declining. The benefit of the modified motion starts to decrease as the StA is increased above ~0.45. The maximum efficiency is achieved at StA = 0.63 for sinusoidal motion
 $\mathrm{\mathbb{T}} = 1.00$. The minimum
 ${\bar{C}_T}$ occurs at
 $\mathrm{\mathbb{T}} = 0.85$, coinciding with the 2P–2S wake boundary (figure 13a). The minimum
 ${\bar{C}_P}$ occurs at
 $\mathrm{\mathbb{T}} = 1.00$ for all StA (figure 13b). When
 $\mathrm{\mathbb{T}}$ is decreased below 1.00, the magnitude of maximum and minimum value of
 ${C_P}$ increase (figure 5a–d). In contrast, for
 $\mathrm{\mathbb{T}} > 1.00$, the increase in
 $\mathrm{\mathbb{T}}$ leads to an increase and decrease in the maximum and minimum magnitudes of
 ${C_P}$ values, respectively (figure 5f–j); however, the increase in
 ${C_P}$ maximum values is larger than the decrease in the
 ${C_P}$ minimum values. This also leads to an increase in the overall
 ${\bar{C}_P}$ with an increase in
 $\mathrm{\mathbb{T}}$, but at a rate slightly higher than when
 $\mathrm{\mathbb{T}}$ in decreased below 1.00 (figure 12b). The η increases with
 $\mathrm{\mathbb{T}}$ and StA for 0.3 ≤ StA < 0.4 (Figure 13c). When StA is further increased, the maximum η slowly shifts from
 $\mathrm{\mathbb{T}} = 1.40$, StA = 0.4 to
 $\mathrm{\mathbb{T}} = 1.00$, StA = 0.53. The decrease in η for
 $\mathrm{\mathbb{T}} > 1.00$ at high StA arises from the large
 $\dot{\theta }$ in the retract stroke (figure 3), with
 ${\bar{C}_P}$ increasing more rapidly than
 ${\bar{C}_T}$.
Contours of average (a) thrust coefficient, (b) input power coefficient and (c) efficiency. The black solid line is the drag–thrust boundary. The dashed lines represents the minimum values of power or thrust against StA. (d) Detailed wake map on the  $S{t_A}- \mathrm{\mathbb{T}}$ plane.

3.4. Effect of foil inertia on power and efficiency
The non-elastic systems are affected by the foil inertia since  ${C_P} < 0$ cannot be used. The foil inertia thus plays an important role in defining the efficiency. It should be noted that we use inertia and moment of inertia interchangeably in this section. We investigate only a single geometry with a uniform density, thus the increase in mass (i.e. density) is reflected in the moment of inertia of the foil. We consider three different moments of inertia, denoted by materials I, II and III. The foil of material I has a very small moment of inertia
 $(J_{zz}^I = 1 \times {10^{ - 5}}\;\textrm{kg - }{\textrm{m}^2})$, and the resulting inertial component of the power is negligible as compared to the fluid component of the power i.e.
 $\bar{C}_{Pi}^ +{\ll} \bar{C}_{Pf}^ + $. The foil of material II has a large moment of inertia
 $(J_{zz}^{II} = 10J_{zz}^I)$, making the inertial and fluid components of the power to be almost equal to each other i.e.
 $\bar{C}_{Pi}^ +{\approx} \bar{C}_{Pf}^ + $. The foil of material III has a very large moment of inertia
 $(J_{zz}^{III} = 10J_{zz}^{II})$, such that the fluid component of the power becomes negligible as compared to the inertial component of the power i.e.
 $\bar{C}_{Pi}^ +{\gg} \bar{C}_{Pf}^ + $. Figure 14 shows
 $C_P^ + $ (black line),
 $C_{Pf}^ + $ (blue line) and
 $C_{Pi}^ + $ (red line) over a complete pitching cycle in the case of StA = 0.38 for materials I (first column), II (second column) and III (third column), and for
 $\mathrm{\mathbb{T}} = 0.80$ (first row), 1.00 (second row) and 1.20 (third row). The
 $C_{Pi}^ + $ and
 $C_{Pf}^ + $ both are zero at ϕ = 90° and 270° (for all materials and
 $\mathrm{\mathbb{T}}$), i.e. at extreme positions of the foil due to
 $\dot{\theta }^{\prime} = 0$. When foil moves away from the extreme positions,
 $C_{Pi}^ + $ and
 $C_{Pf}^ + $ both increase from zero (see e.g.
 $t^{\prime}$ = 0.20, 0.25 and 0.30 for
 $\mathrm{\mathbb{T}} = 0.80$, 1.00 and 1.20, respectively, in figure 14 for all materials), having positive value owing to
 $\dot{\theta }$,
 $\ddot{\theta }$ and −Mz having the same direction (see (2.9) and (2.13)). For all materials, the first peak of
 $C_{Pi}^ + $ occurs at
 $t^{\prime}$ = 0.02, 0.375 and 0.39 for
 $\mathrm{\mathbb{T}} = 0.80$, 1.00 and 1.20, respectively, while that of
 $C_{Pf}^ + $ occurs at
 $t^{\prime}$ = 0.035, 0.44 and 0.40 for
 $\mathrm{\mathbb{T}} = 0.80$, 1.00 and 1.20, respectively. That is,
 $C_{Pi}^ + $ leads
 $C_{Pf}^ + $ (Alam & Muhammad Reference Alam and Muhammad2020). The first peak of
 $C_P^ + $ for materials I, II and III respectively occurs at
 $t^{\prime}$≈ 0.035, 0.025 and 0.02 for
 $\mathrm{\mathbb{T}} = 0.80$, at
 $t^{\prime}$≈ 0.435, 0.405 and 0.38 for
 $\mathrm{\mathbb{T}} = 1.00$ and at
 $t^{\prime}$≈ 0.40, 0.395 and 0.39 for
 $\mathrm{\mathbb{T}} = 1.20$ (figure 14), which indicates that
 $C_{Pi}^ + $ leads
 $C_P^ + $, and
 $C_P^ + $ leads
 $C_{Pf}^ + $. It should be appreciated that
 $C_{Pi}^ + $ could be negative whereas
 $C_P^ + $ by definition is always positive or zero, thus a positive
 $C_{Pf}^ + $ must accompany a negative
 $C_{Pi}^ + $ such that
 $C_P^ + \ge 0$. A similar trend can be observed for
 $\mathrm{\mathbb{T}} = 1.00$ and 1.20 in figures 14(d–f) and 14(g–i), respectively. The peak-to-peak phase difference between
 $C_{Pi}^ + $ and
 $C_P^ + $ decreases with the increase in the moment of inertia.
 $C_P^ + $ (black line),
 $C_{Pf}^ + $ (blue line) and
 $C_{Pi}^ + $ (red line) over a complete pitching cycle in the case of StA = 0.38 for materials I (first column), II (second column) and III (third column), and for
 $\mathrm{\mathbb{T}} = 0.80$ (first row), 1.00 (second row) and 1.20 (third row).

Figure 15 shows variations of  $\bar{C}_{Pf}^ + $,
 $\bar{C}_{Pi}^ + $,
 $\bar{C}_P^ + $ and η + in
 $\mathrm{\mathbb{T}}- S{t_A}$ plane for materials I, II and III in the left, middle and right columns, respectively. The variation of
 $\bar{C}_{Pf}^ + $ is similar to that of
 ${\bar{C}_P}$. There are however two distinctions. First,
 $\bar{C}_{Pf}^ + $ has a slightly larger magnitude than
 ${\bar{C}_P}$. Second, the minimum
 $\bar{C}_{Pf}^ + $ for a given StA occurs at
 $\mathrm{\mathbb{T}} = 1.05$, 1.15, and 1.10 for materials I, II and III, respectively, while
 ${\bar{C}_P}$ is minimum at
 $\mathrm{\mathbb{T}} = 1.00$ (figure 13b). The increase in the moment of inertia decreases
 $\bar{C}_{Pf}^ + $, as can be seen by comparing the colours at any particular StA and
 $\mathrm{\mathbb{T}}$ in figure 15a–c). The
 $\bar{C}_{Pi}^ + $ undoubtedly increases with increasing moment of inertia (see the colourmap ranges for figure 15d–f). The
 $\bar{C}_{Pi}^ + $ first decreases with the increase in
 $\mathrm{\mathbb{T}}$ from 0.80, reaches a minimum at
 $\mathrm{\mathbb{T}} = 1.20$ for material I, and at
 $\mathrm{\mathbb{T}} = 1.00$ for materials II and III, and then increases rapidly with further increase in
 $\mathrm{\mathbb{T}}$. This implies that when
 $\bar{C}_{Pi}^ + \mathrm{\ \mathbin{\lower.3ex\hbox{$\buildrel> \over {\smash{\scriptstyle\sim}\vphantom{_x}}$}}\ }\bar{C}_{Pf}^ + $,
 $\bar{C}_{Pi}^ + $ for the non-elastic system for a particular StA will be minimum at
 $\mathrm{\mathbb{T}} = 1.00$ (see figure 15e,f). The
 $\bar{C}_P^ + $ for materials I and III follows the trends of
 $\bar{C}_{Pf}^ + $ and
 $\bar{C}_{Pi}^ + $, respectively, as
 $\bar{C}_{Pi}^ +{\ll} \bar{C}_{Pf}^ + $ (making
 $\bar{C}_P^ +{\approx} \bar{C}_{Pf}^ + $) for material I and
 $\bar{C}_{Pi}^ +{\gg} \bar{C}_{Pf}^ + $ (making
 $\bar{C}_P^ +{\approx} \bar{C}_{Pi}^ + $) for material III. For material II, because
 $\bar{C}_{Pi}^ +{\approx} \bar{C}_{Pf}^ + $,
 $\bar{C}_P^ + $ follows neither
 $\bar{C}_{Pi}^ + $ nor
 $\bar{C}_{Pf}^ + $. The
 $\bar{C}_P^ + $ decreases with
 $\mathrm{\mathbb{T}}$ increasing from 0.80, becoming minimum at
 $\mathrm{\mathbb{T}} = 1.05$ for materials I and II and at
 $\mathrm{\mathbb{T}} = 1.00$ for material III, and then increases with a further increase in
 $\mathrm{\mathbb{T}}$. The η + for 0.30 < StA ≤ 0.45 increases with
 $\mathrm{\mathbb{T}}$ for
 $0.80 \le \mathrm{\mathbb{T}} \le 1.20$, reaching a maximum at
 $\mathrm{\mathbb{T}} = 1.20$, and then decreases with a further increase in
 $\mathrm{\mathbb{T}}$ for
 $1.20 < \mathrm{\mathbb{T}} \le 1.40$. The η + for StA > 0.45, however, reaches its maximum at
 $\mathrm{\mathbb{T}} = 1.00$. The variations of η+ in the
 $\mathrm{\mathbb{T}}- S{t_A}$ plane for materials II and III are similar to that for material I, except that the peak η + along
 $\mathrm{\mathbb{T}}$ axis for 0.30 < StA < 0.45 occurs at
 $\mathrm{\mathbb{T}} = 1.10$ for material II and at
 $\mathrm{\mathbb{T}} = 1.05$ for material III. For non-elastic storage systems, it can thus be concluded that the moment of inertia should be as low as possible, such that the inertial component of the power becomes negligible in comparison to the fluid power. Moreover, η+ can be enhanced with
 $1.05 < \mathrm{\mathbb{T}} \le 1.20$ for moderate StA (i.e. 0.30 < StA ≤ 0.45), while
 $\mathrm{\mathbb{T}} = 1.00$ is beneficial in terms of η + for StA > 0.45.
Variations of  $\bar{C}_{Pf}^ + $,
 $\bar{C}_{Pi}^ + $,
 $\bar{C}_P^ + $ and
 ${\eta ^ + }$ in the
 $\mathrm{\mathbb{T}}- S{t_A}$ plane for materials I (left column), II (middle column) and III (right column). The colour code bars for
 $\bar{C}_{Pi}^ + $ and
 $\bar{C}_P^ + $ each have three scales for the three materials; left most, material I; middle, material II; and right most, material III. The black line in
 ${\eta ^ + }$ maps corresponds to the drag–thrust transition.

The inertia does not affect  ${\bar{C}_P}$ but plays an important role in determining
 $\bar{C}_P^ + $. This is because
 ${\bar{C}_{Pi}}$ is always zero but
 $\bar{C}_{Pi}^ + $ is positive, its magnitude increasing with increasing the inertia of the foil (figure 15d–f). The effect of inertia is then reflected in efficiency with η + always smaller than η for the respective case. Because
 ${\bar{C}_T}$ is not affected by the inertia, the η + decreases with the increase in inertia as
 $\bar{C}_P^ + > {\bar{C}_P}$ i.e.
 $\bar{C}_{Pi}^ + > 0$.
3.5. Effect of $\mathrm{\mathbb{T}}$ on the wake structure

Intuitively, an increase in pitching amplitude would result in a broader wake as the foil tip excursion is wide, whereas an increase in pitching frequency, owing to centrifugal force (Alam & Muhammad Reference Alam and Muhammad2020), would increase the streamwise velocity in the wake. The focal parameter involved in this study is the kinematics (i.e.  $\mathrm{\mathbb{T}}$). Then, a question naturally arises, what is the effect of
 $\mathrm{\mathbb{T}}$ on the wake? The answer to this question will be given here. Figure 13(d) shows the wake map for the
 $S{t_A}- \mathrm{\mathbb{T}}$ plane. There are only two basic wake patterns, namely 2S for
 $0.85 < \mathrm{\mathbb{T}} \le 1.40$ and 2P for
 $0.80 \le \mathrm{\mathbb{T}} \le 0.85$, including their deflected patterns in small regions (
 $\mathrm{\mathbb{T}} < 1.00$ for StA ≥ 0.43 and for
 $\mathrm{\mathbb{T}} = 0.80$ only when StA = 0.42. The wake deflection will be discussed in a separate section later. We will focus on 2P and 2S patterns only. Figure 16 illustrates the novel 2P wake pattern for
 $\mathrm{\mathbb{T}} = 0.80$ and StA = 0.38. The spanwise non-dimensional vorticity
 $\varOmega _z^\ast ( = {\varOmega _z}d/{U_\infty })$ snapshots are shown for ϕ = 90°, 120°, …, and 0° in figure 16(a–h), overlapped with instantaneous relative streamwise velocity
 $u_r^\ast $ (
 $= (u - {U_\infty })/{U_\infty }$, dashed line) at a streamwise distance
 $x_{TE}^\ast ( = {x_{TE}}/d) = 1.0$, where
 ${x_{TE}}$ is measured from the foil tip at the equilibrium position. The
 $u_r^\ast $ for the
 $\mathrm{\mathbb{T}} = 1.00$ (solid line) is also shown as the baseline. For
 $\mathrm{\mathbb{T}} = 0.80$, during the slower retract stroke (ϕ = 90°–180°), a positive (counterclockwise) vortex
 ${\rm A}^{\prime}$ impinges along the lower surface, and another positive vortex A grows from the foil's tip (figure 16a,b). The formation of vortex A stems from the foil tip inertia (or can be said to arise from the flow separation at the tip) while that of vortex
 ${\rm A}^{\prime}$ originates from the flow separation at the leading edge. However, a negative vortex
 ${\rm B}^{\prime}$ originating from the leading edge impinges on the upper surface. During this slower retract stroke (ϕ = 90°–180°, figure 16a–d), the tip vortex A grows and sheds above the wake centreline (y* = 0) while the vortices
 ${\rm A}^{\prime}$ and
 ${\rm B}^{\prime}$ roll down over the lower and upper surfaces of the foil, respectively. The
 $u_r^\ast $ strengthens around the wake centreline when the foil moves from ϕ = 90° to 180° while
 $u_r^\ast $ around vortex A is negative (figure 16c,d).
Contours of  $\varOmega _z^\ast $ showing generation and evolution of 2P wake (StA = 0.38,
 $\mathrm{\mathbb{T}} = 0.80$) at ϕ = 90°, 120°, …, 270° in (a–g) and ϕ = 0° in (h). The
 $\varOmega _z^\ast{\in} [ - 5,5]$, with positive
 $\varOmega _z^\ast $ shaded in red and negative
 $\varOmega _z^\ast $ shaded in blue. The corresponding
 $u_r^\ast = (u - {U_\infty })/{U_\infty }$ profiles (dashed line) are given at
 $x_{TE}^\ast = ((x - {x_{TE}})/d) = 1$. The solid line represents
 $u_r^\ast $ for
 $\mathrm{\mathbb{T}} = 1.00$. The horizontal and vertical lines represent y* = 0 and
 $u_r^\ast \; = 0$, respectively.

The forward stroke (ϕ = 180°–270°, figure 16d–g) is very fast (lowest  $\mathrm{\mathbb{T}} = 0.80$ examined), hence generating a very high acceleration. The foil tail thus leaves the wake centreline (equilibrium position) very fast, leaving vortex A above the wake centreline. This phenomenon is akin to the magic trick that when a sheet of paper on a table, with a coin on the top of the sheet, is pulled horizontally with a quick snap, the coin remains on the table, rather than moving with the paper. In the meanwhile, vortex
 ${\rm A}^{\prime}$ arriving at the foil tip reforms itself as the forward stroke is faster (ϕ = 180°–270°, figure 16d–g). Vortex
 ${\rm A}^{\prime}$ lies abreast of vortex A, closer to the foil tip, merging with the braid shear-layer. Vortices A and
 ${\rm A}^{\prime}$ bundle together and form a paired vortex (figure 16g). Vortex
 ${\rm A}^{\prime}$, however, has a higher streamwise velocity than vortex A as
 ${\rm A}^{\prime}$ forms in the faster stroke (higher centrifugal force) and lies close to the wake centreline. The velocities of A and
 ${\rm A}^{\prime}$ could be understood from the corresponding
 $u_r^\ast $ values around them. The return of the foil (ϕ = 270°–0°, figure 16(g,h) further accelerates vortex
 ${\rm A}^{\prime}$. The merging line connecting A–
 ${\rm A}^{\prime}$ centres thus rotates anticlockwise, see the
 $u_r^\ast $ profile and snapshots at ϕ = 270° and 0°. The same rotation signs of the individual vortices and of merging line facilitate the merging of the two vortices into one vortex in the next two strokes, which can also be seen from the evolution of the negative (blue coloured) paired vortices from ϕ = 180° to 0° (figure 16d–h). Similarly, vortex B forms as a tip inertia vortex from ϕ = 270° to 0°. Overall, the paired vortices during their downstream evolution evolve into a single vortex in about two vortex-shedding cycles. The wake thus features 2P vortices up to 5d downstream from the foil tip and 2S vortices afterward.
There are several noticeable differences between the  $u_r^\ast $ profiles for
 $\mathrm{\mathbb{T}} = 0.80$ and 1.00. First, at ϕ = 90° (figure 16a), the braid shear-layer for
 $\mathrm{\mathbb{T}} = 1.00$ (figure 6e) is replaced by a vortex for
 $\mathrm{\mathbb{T}} = 0.80$, as can be seen from higher
 $u_r^\ast $ for
 $\mathrm{\mathbb{T}} = 0.80$ than for
 $\mathrm{\mathbb{T}} = 1.00$ above the wake centreline. When the foil moves from the upper extreme to the lower extreme,
 $u_r^\ast $ at y* < 0 (lower side of the wake) is greater for
 $\mathrm{\mathbb{T}} = 0.80$ than for
 $\mathrm{\mathbb{T}} = 1.00$ (figure 16b–g). Similarly, when the foil travels from the lower extreme to the upper (figure 16g,h), the
 $u_r^\ast $ at y* < 0 is enhanced for
 $\mathrm{\mathbb{T}} = 0.80$.
The wake for  $\mathrm{\mathbb{T}} = 1.20$, however, is simply characterized by 2S vortices (figure 17), in a very similar fashion to that for
 $\mathrm{\mathbb{T}} = 1.00$ (figure 6c–f). The tip vortex A rapidly grows from ϕ = 90° to 180° (faster stroke, figure 17a–d). Because of the faster foil rotation, vortex A is better concentrated and closer to the foil tip than its counterpart for = 0.80 in ϕ = 90° to 180° (slower stroke, see figure 16a–d). The leading-edge vortex
 ${\rm A}^{\prime}$ flattens and dies out when the foil travels from the upper extreme to the equilibrium. It further dies out in the forward stroke (figure 17d–g) and could not reach vortex A (figure 17f). It, however, contributes to vorticity in the braid shear-layer (figure 17f,g). The vortex
 ${\rm A}^{\prime}$ does not present itself in the wake. A single vortex is thus born in the wake when the foil travels from the upper extreme to the lower extreme. Similarly, another single vortex B comes into being when the foil returns to the upper extreme i.e. ϕ = 270° to 0° to 90° (figure 17a,g,h). Comparing the snapshots for ϕ = 180°–270° between
 $\mathrm{\mathbb{T}} = 0.80$ (figure 16d–g) and 1.20 (figure 17d–g), one can understand that vortex
 ${\rm A}^{\prime}$ for
 $\mathrm{\mathbb{T}} = 0.80$ can reform itself in the wake, induced by the faster movement of foil tip (faster stroke) while that for
 $\mathrm{\mathbb{T}} = 1.20$ cannot reform as the foil tip moves slowly. The
 $u_r^\ast $ profile for
 $\mathrm{\mathbb{T}} = 1.20$ closely mimics that for
 $\mathrm{\mathbb{T}} = 1.00$ for most part of the cycle, except at ϕ = 210°–270° (just before reaching the extreme position). It can be seen that the vortex in the wake (e.g. vortex A in figure 17f) for
 $\mathrm{\mathbb{T}} = 1.20$ is stronger than its counterpart for
 $\mathrm{\mathbb{T}} = 1.00$, which accompanies a sudden burst of instantaneous
 $u_r^\ast $. Figure 18 shows wake structures for StA = 0.38 at
 $\mathrm{\mathbb{T}} = 1.40$, where the
 $u_r^\ast $ profiles at
 $x_{TE}^\ast = 1$ for
 $\mathrm{\mathbb{T}} = 1.00$ and 1.40 are overlaid onto the vorticity contours as solid and dashed lines, respectively. Like
 $\mathrm{\mathbb{T}} = 1.20$, the
 $\mathrm{\mathbb{T}} = 1.40$ also exhibits 2S wake, but with higher peak vorticity of the vortices (not shown). In addition, the vortices (e.g. A in figure 18d) form closer to the trailing edge when compared to the case of a smaller
 $\mathrm{\mathbb{T}}$ (e.g. compare vortex A in figures 14d, 15d and 16d). The
 $u_r^\ast $ profiles are qualitatively similar to those for
 $\mathrm{\mathbb{T}} = 1.20$.
Contours of  $\varOmega _z^\ast $ showing generation and evolution of 2S wake (StA = 0.38,
 $\mathrm{\mathbb{T}} = 1.20$) at ϕ = 90°, 120°, …, 270° in (a–g) and ϕ = 0° in (h). The
 $\varOmega _z^\ast{\in} [ - 5,5]$, with positive
 $\varOmega _z^\ast $ shaded in red and negative
 $\varOmega _z^\ast $ shaded in blue. The corresponding
 $u_r^\ast = (u - {U_\infty })/{U_\infty }$ profiles (dashed line) are given at
 $x_{TE}^\ast = ((x - {x_{TE}})/d) = 1$. The solid line represents
 $u_r^\ast $ for
 $\mathrm{\mathbb{T}} = 1.00$. The horizontal and vertical lines represent y* = 0 and
 $u_r^\ast \; = 0$, respectively.

Contours of  $\varOmega _z^\ast $ showing generation and evolution of 2S wake (StA = 0.38,
 $\mathrm{\mathbb{T}} = 1.40$) at ϕ = 90°, 120°, …, 270° in (a–g) and ϕ = 0° in (h). The
 $\varOmega _z^\ast{\in} [ - 5,5]$, with positive
 $\varOmega _z^\ast $ shaded in red and negative
 $\varOmega _z^\ast $ shaded in blue. The corresponding
 $u_r^\ast = (u - {U_\infty })/{U_\infty }$ profiles (dashed line) are given at
 $x_{TE}^\ast = ((x - {x_{TE}})/d) = 1$. The solid line represents
 $u_r^\mathrm{\ast }$ for
 $\mathrm{\mathbb{T}} = 1.00$. The horizontal and vertical lines represent y* = 0 and
 $u_r^\ast \; = 0$, respectively.

Indeed, observing the wake structures in the entire range of StA and  $\mathrm{\mathbb{T}}$, we identified novel 2P reverse Kármán wake (figure 16), 2S reverse Kármán wake (figures 15 and 16) and asymmetric wake. The 2S Kármán or 2S aligned wake was not observed even at the lowest StA (= 0.23) investigated here; this is in accordance with the wake map from the experimental work of Schnipper et al. (Reference Schnipper, Andersen and Bohr2009). The novel 2P reverse Kármán wake observed here is quite different from the 2P wake observed by Schnipper et al. (Reference Schnipper, Andersen and Bohr2009). The pairs observed in the present study have the same signed vortices such as A-
 ${\rm A}^{\prime}$, contrary to the opposite signed vortices (see figure 3 of Schnipper et al. Reference Schnipper, Andersen and Bohr2009). Presently, the paired vortices form a single vortex downstream as having the same sign of vorticity. The paired vortices having different signs of vorticity do not merge, the wake appearing 2P far downstream (Schnipper et al. Reference Schnipper, Andersen and Bohr2009).
The time-averaged streamwise  $\bar{u}_r^\ast $ profiles in the wake for
 $\mathrm{\mathbb{T}} = 0.80$, 1.00, 1.20 and 1.40 shown in figure 19 as dashed, continuous, dash–dotted line and dotted lines, respectively display that
 $\bar{u}_r^\ast $ is largely negative for |y*| = 0.65–1.25 (depending on
 $\mathrm{\mathbb{T}}$). This suggest a buffer (velocity deficit) zone between the wake jet (velocity excess) and the free stream, induced by the positive and negative vortices above and below the wake centreline. The
 $\bar{u}_r^\ast $ around the wake centreline is very high (e.g. at
 $x_{TE}^\ast = 1.00$; figure 19a), the maximum
 $\bar{u}_r^\ast = 0.82$, 1.05, 1.24 and 1.45 for
 $\mathrm{\mathbb{T}} = 0.80$, 1.00, 1.20 and 1.40, respectively, i.e. the maximum averaged streamwise velocity reaches 182 %, 205 %, 224 % and 245 % of the freestream velocity, respectively, which indicates a jet-like flow. With the increase in
 $\mathrm{\mathbb{T}}$, the
 $\bar{u}_r^\ast $ peak on the wake centreline extends at both
 $x_{TE}^\ast $ values, while the wake width
 $(\bar{u}_r^\ast > 0)$ narrows significantly at
 $x_{TE}^\ast = 1.00$ but negligibly at
 $x_{TE}^\ast = 6.00$ (figure 19b). The increased peak
 $\bar{u}_r^\ast $ with increasing
 $\mathrm{\mathbb{T}}$ is, to some extent, linked to stronger vortices for the higher
 $\mathrm{\mathbb{T}}$ (figure 18f).
The cross-stream variation of non-dimensionalized time-average streamwise wake velocity  $(\bar{u}_r^\ast = (\bar{u} - {U_\infty })/{U_\infty })$ with
 $\mathrm{\mathbb{T}}$ at (a)
 $x_{TE}^\ast = ((x - {x_{TE}})/d) = 1$ and (b)
 $x_{TE}^\ast = 6$ measured from the foil tip for StA = 0.38.

Increasing A* means increasing foil tip excursion; one thus expects an increased wake width. The flow centrifugal force arising from the foil rotation results from the maximum tip velocity that grows with increasing Std or A* or both (see (2.4)). The maximum tip velocity is thus connected to the streamwise velocity around the wake centreline. This raises a question, what is the effect of  $\mathrm{\mathbb{T}}$ on the wake width and wake velocity when changing
 $\mathrm{\mathbb{T}}$ that changes neither A* nor Std? These simple intuitive arguments have not been addressed in the literature. We would like to shed some light on this point. Figure 20 shows the dependence of wake width w* (= w/d) on the
 $\mathrm{\mathbb{T}}$, A* and Std, where w is the jet width at
 $x_{TE}^\ast = 1.00$, defined by the cross-stream length for
 $\bar{u}_r^\ast > 0$. Figure 20(a–c) shows the dependence of w* on
 $\mathrm{\mathbb{T}}$ and A* at different Std values, whereas figure 20(d–f) shows the same on
 $\mathrm{\mathbb{T}}$ and Std at different A* values.
Contour maps of normalized wake width w* = (w/d) at  $x_{TE}^\ast = 1$ for (a) Std = 0.21, (b) Std = 0.27, (c) Std = 0.33, (d) A* = 1.1, (e) A* = 1.3 and (f) A* = 1.6. The black contour lines in panels (c)–(d) show w* = A*.

The w* grows with increasing A* for a given  $\mathrm{\mathbb{T}}$ but declines with increasing
 $\mathrm{\mathbb{T}}$ for a given A* (figure 20a–c). That is, the
 $\mathrm{\mathbb{T}}$ effect on w* is opposite to the A* effect. The
 $\mathrm{\mathbb{T}}$ effect on w* although looking straightforward, a deeper explanation can be provided, which links with fluid angular momentum that is essentially a representation of
 ${C_{Pf}}$. Indeed, the forward stroke is more connected to w* than the retract stroke as the forward stroke diverges fluid away from the wake centreline while the retract stroke brings fluid toward the wake centreline, albeit not at the same scale. For
 $\mathrm{\mathbb{T}} = 1.00$, the angular momentum varies similarly in the forward and retract strokes (figure 6a). When
 $\mathrm{\mathbb{T}}$ is decreased from 1.00, the faster forward stroke causes a large variation in
 ${C_{Pf}}$ in the forward stroke (figure 8a), diverging the fluid away from the wake centreline with a large angular momentum. The w* thus widens with decreasing
 $\mathrm{\mathbb{T}}$ from 1.00. In contrast, when
 $\mathrm{\mathbb{T}}$ is increased from 1.00, the forward stroke becomes slower and has a smaller variation in
 ${C_{Pf}}$ than the retract stroke (figures 7a and 8a). The smaller angular momentum during the forward stroke thus corresponds to a narrower w*. Another feature is that the decrease in w* with increasing
 $\mathrm{\mathbb{T}}$ is not linear, rather faster at lower
 $\mathrm{\mathbb{T}}$, as can be observed from steeper slopes of the contour lines at lower
 $\mathrm{\mathbb{T}}$ (figure 20a–c). At a constant A*, the w* boosts with increasing Std particularly for
 $\mathrm{\mathbb{T}} > 1.00$ (figure 20d–e) as a higher oscillation frequency produces more angular momentum. The effect of Std on w*, however, diminishes with increasing A* (figure 20d–f). The peak-to-peak amplitude A* instead of the half-amplitude is adopted in most of the literature as it is assumed to represent wake width as well. A scrupulous observation on w* contours suggests that w* is larger than A* for
 $\mathrm{\mathbb{T}} = 1.00$ and is also a function of Std (see figure 20d–f).
The jet produced in the wake is expected to be highly connected to  ${\bar{C}_T}$. The maximum jet velocity in the wake is a measure of the jet strength. It is worth studying the dependence of jet velocity on A*,
 $\mathrm{\mathbb{T}}$ and Std. We measured the maximum jet velocity as the maximum time-average streamwise velocity
 $\bar{u}_{r,max}^\ast ( = max(\bar{u}_r^\ast ))$ at
 $x_{TE}^\ast = 1.00$. The dependence of
 $\bar{u}_{r,max}^\ast $ can be understood from the contour plots of
 $\bar{u}_{r,max}^\ast $ on the
 ${A^\ast }- \mathrm{\mathbb{T}}$ and
 $S{t_d}- \mathrm{\mathbb{T}}$ planes in figure 21. An increase in
 $\mathrm{\mathbb{T}}$ and/or A* results in a monotonic increase in
 $\bar{u}_{r,max}^\ast $ (figure 21a–c). This is consistent with the fact that
 ${\bar{C}_T}$ enhances with increasing
 $\mathrm{\mathbb{T}}$ and/or A*. At a given
 $\mathrm{\mathbb{T}}$, an increase in Std leads to an increased
 $\bar{u}_{r,max}^\ast $ (figure 21d–f). Overall, increasing
 $\mathrm{\mathbb{T}}$ from 1.00 strengthens the jet (increasing
 $\bar{u}_{r,max}^\ast $), which narrows the w*, whereas decreasing
 $\mathrm{\mathbb{T}}$ from 1.00 widens the jet (increasing w*), which weakens the jet. It is worth noting that the jet characteristics can be modified by changing
 $\mathrm{\mathbb{T}}$ only for constant Std and A*. For a sinusoidal pitching foil, increasing A* is capable of both strengthening and widening the jet. However, increasing Std largely fortifies the jet, with negligible influence on the jet width. The effects of
 $\mathrm{\mathbb{T}}$ on Std, A*, StA,
 ${\bar{C}_T}$,
 ${\bar{C}_P}$, w, and
 $\bar{u}_{r,max}^\ast $ are summarized in table 2.
Contour maps of normalized maximum wake velocity  $\bar{u}_{r\textrm{,}max\; }^\ast $ at
 $x_{TE}^\ast = 1$ for (a) Std = 0.21, (b) Std = 0.27, (c) Std = 0.33, (d) A* = 1.1, (e) A* = 1.3 and (f) A* = 1.6.

Effect of  $\mathrm{\mathbb{T}}$ on
 ${\bar{C}_T}$,
 ${\bar{C}_P}$, η, w*, and
 $\bar{u}_{r,max}^\ast $.

Effect of Std, A* and StA on  ${\bar{C}_T}$,
 ${\bar{C}_P}$, η, w* and
 $\bar{u}_{r,max}^\ast $.

When  $\mathrm{\mathbb{T}}$ is increased from 0.80 to 1.40, both
 ${\bar{C}_T}$ and
 ${\bar{C}_P}$ first decrease and then increase, having minimum at
 $\mathrm{\mathbb{T}} = 0.85$ and 1.00, respectively. However, η for 0.3 < StA < 0.4 increases monotonically with
 $\mathrm{\mathbb{T}}$ while that for StA > 0.4 first increases and then decreases with
 $\mathrm{\mathbb{T}}$. For the drag regime, η has a minimum at
 $\mathrm{\mathbb{T}} = 0.90$, with η decreasing and increasing for
 $0.80 \le \mathrm{\mathbb{T}} < 0.90$ and
 $0.90 < \mathrm{\mathbb{T}} \le 1.40$, respectively (table 2). The w*, however, monotonically declines and
 $\bar{u}_{r,max}^\ast $ grows with increasing
 $\mathrm{\mathbb{T}}$. The parameters Std, A* and StA are linked to one another in a fashion of
 $S{t_A} = S{t_d} \times {A^\ast }$. Hence, a change in Std and/or A* modifies StA. When StA is increased by increasing Std or A*, the
 ${\bar{C}_T}$ and
 ${\bar{C}_P}$ increase exponentially and
 $\bar{u}_{r,max}^\ast $ increases linearly. The w* increases with StA if Std is held constant and if A* is constant, then w* decreases with StA from
 $0.80 \le \mathrm{\mathbb{T}} < 0.90$ and it increases with StA for
 $0.90 < \mathrm{\mathbb{T}} \le 1.40$ (table 3).
3.5.1. Deflected wakes and $\mathrm{\mathbb{T}}$ effect on wake asymmetry

The deflected (asymmetric) wake was found at small  $\mathrm{\mathbb{T}}$ and large StA, as seen in figure 13(d) (upper-left corner). The averaged wake jet deflection angle θw was measured by a linear fit of the cross-stream position of
 $\bar{u}_{r,max}^\ast $ in the near wake
 $(1 \le x_{TE}^\ast \le 10)$ as shown in figure 22(a). This method of estimating θw was proposed by Godoy-Diana et al. (Reference Godoy-Diana, Marais, Aider and Wesfreid2009). The θw for StA = 0.43 against
 $\mathrm{\mathbb{T}}$ is shown in figure 22(b). The negative value of θw indicates the wake deflecting downward. The wake is symmetric for
 $\mathrm{\mathbb{T}} = 1.00- 1.40$ (i.e. θw = 0°) and becomes asymmetric when
 $\mathrm{\mathbb{T}}$ is decreased from 1.00, θw = −9.3° at the lowest
 $\mathrm{\mathbb{T}}$ ( = 0.80) examined. As shown in figure 13(d), at StA = 0.429, asymmetric wake is only seen at
 $\mathrm{\mathbb{T}} = 0.80$, however, when the StA is increased slightly (i.e. StA = 0.432), the asymmetric wake appears at higher
 $\mathrm{\mathbb{T}}$ (
 $0.80 \le \mathrm{\mathbb{T}} < 1.00$, see figure 13d). The metamorphosis of the symmetric wake into the deflected wake at
 $\mathrm{\mathbb{T}} < 1.00$ arises from the slower retract stroke generating vortices further away from the foil tip (e.g. compare vortex A in figure 16d to that in figure 17d). Thus, the distance between the two completely shed nearest counter-rotating vortices in the near wake shrinks. For example, vortices
 ${\rm A}^{\prime}$ and B in figure 16(h)
 $(\mathrm{\mathbb{T}} = 0.80)$ are closer to each other than vortices A and B in figure 17(h)
 $(\mathrm{\mathbb{T}} = 1.20)$. This makes them susceptible to forming a dipole vortex pair with a vortex of the opposite sign of rotation shed in the previous half-cycle. The formation of the vortex pair triggers the wake asymmetry (Marais et al. Reference Marais, Thiria, Wesfreid and Godoy-Diana2012). This is clearly depicted in figure 22(c–f) where the vorticity contours behind the foil pitching for
 $\mathrm{\mathbb{T}} = 1.40$, 1.20, 1.00 and 0.80 are shown, respectively. The distance (normalized with d) between the first two completely shed vortices (opposite signed) is measured and marked in figure 22(c–e). The distance is measured between the locations of maximum and minimum vorticities. It can be seen that a decrease in
 $\mathrm{\mathbb{T}}(0.80 \le \mathrm{\mathbb{T}} \le 1.20)$ is accompanied by decreasing distance between two opposite sign vortices, which leads to increasing the chance for the asymmetric wake formation.
(a) The wake deflection angle measured by linear fit of maximum wake velocity points (circles) in near wake (for  $\mathrm{\mathbb{T}} = 0.80$, StA = 0.432), dash–dotted line and dashed line depict y* = 0 and least square fit for the near wake deflection angle
 $(1 \le x_{TE}^\ast \le 10)$. (b) The wake deflection angle against
 $\mathrm{\mathbb{T}}$. Vorticity contours for
 $\mathrm{\mathbb{T}} = 1.40$, 1.20, 1.00, and 0.80 in (c), (d), (e) and (f), respectively. All data in panels (a–f) are for StA = 0.432.

3.6. Discussion
Here, we pay attention to the origin of thrust and the effect of  $\mathrm{\mathbb{T}}$ on it. The StA will thus be assumed constant for this discussion. As discussed by Alam & Muhammad (Reference Alam and Muhammad2020), the
 $\dot{\theta }$ and
 $\ddot{\theta }$ have a strong correlation with forces (surface pressure) and moments on the foil, while the qualitative vortex structure does not change much. The averaged forces and moments on a foil, however, do correlate to the averaged flow field in the wake. There are a few interesting points on the effect of
 $\mathrm{\mathbb{T}}$ on thrust and wake flow, where physical insight into them should be explored. For example, why does the wake widen with decreasing
 $\mathrm{\mathbb{T}}$? Why is thrust robust at a high
 $\mathrm{\mathbb{T}}$?
The momentum balance in the streamwise direction does point out the wake relation to (average) thrust. As mentioned in the introduction, the streamwise momentum balance over-estimates thrust. The underlying cause is that pitching motion is purely a rotational motion, which induces the rotational motion of the fluid surrounding the foil and the generation of streamwise momentum of fluid is a reaction of rotational motion of the foil on fluid. The correlation between average thrust and jet wake thus gives rise to the post hoc ergo propter hoc fallacy, whereby an assumption is made that thrust is the reaction of streamwise jet and vice versa. In this case, correlation does not imply causation. They (thrust and jet wake) are essentially inter-dependent and contingent on the angular motion of the foil. Naturally, we then need to understand the relationship of the foil motion (θ,  $\dot{\theta }$,
 $\ddot{\theta }$) to thrust and wake. The
 ${C_T}$ and wake characteristics (such as
 $u_r^\ast $) should follow the respective
 $\dot{\theta }$ that produces a centrifugal jet owing to the centrifugal acceleration (Alam & Muhammad (Reference Alam and Muhammad2020).
The  $\dot{\theta }$ profile for
 $\mathrm{\mathbb{T}} < 1.00$ and
 $\mathrm{\mathbb{T}} > 1.00$ are mirror images of each other (see e.g.
 $\mathrm{\mathbb{T}} = 0.80$ and 1.20 in figure 3b) while the difference in
 ${\bar{C}_T}$ for
 $\mathrm{\mathbb{T}} < 1.00$ and
 $\mathrm{\mathbb{T}} > 1.00$ (see e.g. figure 5a,i) can be understood by the phenomenon of the resonance between natural
 $(\mathrm{\mathbb{T}} = 1.00)$ vortex shedding and modified motion
 $(\mathrm{\mathbb{T}})$ vortex shedding. During the natural vortex shedding (
 $\mathrm{\mathbb{T}} = 1.00$, figure 6c–f), most of the tip shear-layer roll-up occurs in the retract stroke. By speeding up the retract stroke for
 $\mathrm{\mathbb{T}} > 1.00$, a resonance is created between the natural tip shear-layer roll-up and the increased
 $\dot{\theta }$ of the foil. Hence, a stronger jet is formed behind the foil with
 $\mathrm{\mathbb{T}} > 1.00$ accompanying higher
 ${\bar{C}_T}$. When
 $\mathrm{\mathbb{T}}$ is decreased from 1.00, the tip shear-layer roll-up process slows down in the slower retract stroke and speeds up in the faster forward stroke. The slower retract stroke causes a decreased
 $\bar{u}_r^\ast $ owing to the slowed roll-up of the shear layer at the tip of the foil, while the fast forward stroke not only adds additional vorticity to the tip shear-layer but also flings the flow outward (away from the symmetry) and hence increases w*. Thus, the loss of
 ${\bar{C}_T}$ arising from weaker tip shear-layer roll-up in the retract stroke (for
 $\mathrm{\mathbb{T}} = 0.80$) is compensated by the increased w* and stronger tip-shear-layer roll-up in the faster forward stroke. There is a net decrease in
 ${\bar{C}_T}$ with
 $\mathrm{\mathbb{T}}$ for
 $\mathrm{\mathbb{T}} < 1.00$ until
 $\mathrm{\mathbb{T}} = 0.85$ (figure 12a), where the increased shear-layer contribution in the forward stroke enhances and creates an additional vortex (such as A′ in figure 16). This additional vortex is accompanied by increased w* that compensates for the loss of jet velocity; thus
 ${\bar{C}_T}$ starts increasing for
 $\mathrm{\mathbb{T}} < 0.85$. The
 ${\bar{C}_P}$ is higher for
 $\mathrm{\mathbb{T}} > 1.00$ than for
 $\mathrm{\mathbb{T}} < 1.00$, but owing to resonance in the natural vortex shedding process and induced vortex shedding, η for
 $\mathrm{\mathbb{T}} > 1.00$ is higher than that for
 $\mathrm{\mathbb{T}} < 1.00$ (for a constant StA > 0.30). To quantify the increase or decrease of the tip shear-layer roll-up contribution, we measured the circulation of the shed vortices by integrating the vorticity times the area. Visual inspection of the wake from figures 6(c–f), 14, 15 and 16, showed that most of the lower surface shear-layer roll-up behind the foil tip occurs between phase 90°–180° (i.e. from the extreme position to the equilibrium position). The circulation around the vortex A or A–
 ${\rm A}^{\prime}$ (whichever the case may be) at ϕ = 180° (figures 14–16) was 64 %, 76 %, 89 % and 99 % of the circulation about the same vortex A or A-
 ${\rm A}^{\prime}$ at ϕ = 270°, for
 $\mathrm{\mathbb{T}} = 0.80$, 1.00, 1.20 and 1.40, respectively. This shows that the contribution of the shear-layer to the shed vorticity for the forward stroke (ϕ = 180° to 270°) becomes higher with decreasing
 $\mathrm{\mathbb{T}}$. For the sinusoidal motion, 76 % of the shear-layer roll-up (on one side of the foil, during a cycle) is done in the retract stroke (ϕ = 90° to 180°). The speeding up of the retract stroke
 $(\mathrm{\mathbb{T}} > 1.00)$ resonates with the natural cycle of the shear-layer roll-up process (i.e. for
 $\mathrm{\mathbb{T}} = 1.00$), thus the
 ${\bar{C}_T}$ and η are both reinforced as compared to those from
 $\mathrm{\mathbb{T}} = 1.00$ (figure 12a,c). Conversely, for
 $\mathrm{\mathbb{T}} < 1.00$, the natural roll-up process (i.e. like that for
 $\mathrm{\mathbb{T}} = 1.00$) is disturbed, thus we see a decrease in
 ${\bar{C}_T}$ and η for
 $\mathrm{\mathbb{T}} < 1.00$, except for
 $\mathrm{\mathbb{T}} = 0.80$ (figure 12a,c), where the shear-layer roll-up process gets in tune with the kinematics again and a much stronger
 ${\rm A}^{\prime}$ vortex starts shedding in the wake in the forward stroke (figure 16d–g), which compensates for the weakened tip vortex (e.g. vortex A) enough to gain additional thrust.
The Std and A* ranges of the current study do not contain the optimal Std and A* combination for peak thrust. Nevertheless, in this sub-optimal range of parameters, we do get thrust and efficiency enhancements by altering the kinematics of the pitching foil. From the literature, we know the efficiency has a single maximum in the Std–A* plane (Triantafyllou et al. Reference Triantafyllou, Triantafyllou and Gopalkrishnan1991, Reference Triantafyllou, Triantafyllou and Grosenbaugh1993; Mackowski & Williamson Reference Mackowski and Williamson2015). This means that if all the maxima of peak efficiency in the Std–A* plane are joined with a line, it could show us the optimal efficiency in the three-parameter study undertaken here. Because the line of maxima is outside the studied ranges of parameters, we plotted the steepest ascent lines for the efficiency enhancement in figure 23. The steepest ascent lines are the streamlines of the gradient field with respect to the input parameters, i.e. 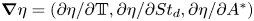 $\boldsymbol{\nabla }\eta = (\partial \eta /\partial \mathrm{\mathbb{T}},\partial \eta /\partial S{t_d},\partial \eta /\partial {A^\ast })$. The steepest ascent lines lead to the global optimum and indicate the response sensitivity (for more details see Fernex et al. Reference Fernex, Semaan, Albers, Meysonnat, Schröder and Noack2020). The steepest ascent lines seem to converge at
 $\mathrm{\mathbb{T}} = 1.00$, A* = 1.6 and Std ≈ 0.4. The optimal Std decreases with increasing A*. The StA corresponding to the optimum η is ≈ 0.63 that is within the range of natural swimmers (see A2 for details). The figure further demonstrates that at large StA, beyond the maximum η, the flow becomes chaotic, as such the enhancement of η and
 ${\bar{C}_T}$ does not hold anymore. The
 $\mathrm{\mathbb{T}} > 1.00$ at large StA (>0.5) is thus not effective anymore in terms of η. This however does not undermine the importance of employing
 $\mathrm{\mathbb{T}}$ for lower StA as the fish and marine animals do not always swim at optimum efficiency.
The steepest ascent curves coloured with efficiency, with the iso-contour (grey surfaces) showing three levels of η.

4. Conclusions
The previous works on foil with different modified pitching motion reported either enhanced thrust or enhanced efficiency, which revealed the necessity to find a way to enhance both thrust and efficiency simultaneously. Here we have introduced a novel modified pitching motion inspired by nature and investigated the hydrodynamics of a foil undergoing the novel modified pitching motion. The novel pitching motion includes a variation in the time period ratio  $\mathrm{\mathbb{T}}$ in [0.80, 1.40], featuring a competition between the foil speeds in forward and retract strokes, with
 $\mathrm{\mathbb{T}} > 1.00$ giving the faster retract stroke than the forward stroke and vice versa with
 $\mathrm{\mathbb{T}} < 1.00$. The Std (= 0.21–0.33) and A* (= 1.1–1.6) of the pitching foil have also been varied to show the benefit of the modified pitching motion over the range of operating conditions.
The relationship between  ${C_T}$ and
 ${C_P}$ changes substantially with
 $\mathrm{\mathbb{T}}$. A decrease in
 $\mathrm{\mathbb{T}}$ from 1.00 to 0.80 makes the
 ${C_T}$ and
 ${C_P}$ peaks move away from each other, almost out of phase at
 $\mathrm{\mathbb{T}} = 0.80$ where the
 ${C_T}$ peak coincides with the
 ${C_P}$ valley and vice versa. Increasing
 $\mathrm{\mathbb{T}}$ from 1.00 to 1.40 causes the
 ${C_T}$ and
 ${C_P}$ peaks to move towards each other so that they are almost in-phase at
 $\mathrm{\mathbb{T}} = 1.40$. The characteristics and results of
 $\mathrm{\mathbb{T}} > 1.00$ motions in the faster stroke bear a resemblance to the fast start of a prey fish to escape while those of
 $\mathrm{\mathbb{T}} < 1.00$ correspond to the braking locomoton for fish swimming.
An increase in  $\mathrm{\mathbb{T}}$ from 1.00 enhances
 ${\bar{C}_T}$,
 ${\bar{C}_P}$ and η, for example by 25.2 %, 14.5 % and 8.5 % at
 $\mathrm{\mathbb{T}} = 1.20$, and by 105 %, 86 % and 10 % at
 $\mathrm{\mathbb{T}} = 1.40$ with StA = 0.38. The enhancement is attributed to the synchronization between the natural vortex shedding
 $(\mathrm{\mathbb{T}} = 1.00)$ and the contribution of modified pitching motion to the vortex shedding, with the retract stroke making the vortices faster and stronger. As a result, the wake width shrinks and the maximum jet velocity increases in the wake. Larger
 ${\bar{C}_P}$ is required when
 $\mathrm{\mathbb{T}}$ is increased from 1.00 as an increased speed of pitching undergoes an increased flow resistance. For StA > 0.4, the η increases for
 $0.80 \le \mathrm{\mathbb{T}} \le 1.20$ and decreases for
 $\mathrm{\mathbb{T}} > 1.20$. With a further increase in StA (>0.5), the η peaks at
 $\mathrm{\mathbb{T}} = 1.00$. A decrease in
 $\mathrm{\mathbb{T}}$ from 1.00 also requires higher
 ${\bar{C}_P}$ for the same reason, as the only difference between
 $\mathrm{\mathbb{T}} > 1.00$ and T < 1.00 is the faster and slower strokes swapping with each other. The
 ${\bar{C}_P}$ is minimum at
 $\mathrm{\mathbb{T}} = 1.00$ while
 ${\bar{C}_T}$ is at
 $\mathrm{\mathbb{T}} = 0.85$. A 2P wake is observed for
 $\mathrm{\mathbb{T}} \le 0.85$, which shares the boundaries with the minimum
 ${\bar{C}_P}$.
The  ${\bar{C}_{Pi}}$ is always zero while
 $\bar{C}_{Pi}^ + $ is always greater than zero. This is because for perfectly elastic energy storage systems,
 ${C_{Pi}} > 0$ and
 ${C_{Pi}} < 0$ cancel each other; however,
 ${C_P} < 0$ cannot be used for non-elastic energy storage systems. The
 $\bar{C}_{Pi}^ + $ increases with increasing foil inertia. The
 $\bar{C}_{Pf}^ + $ and
 $\bar{C}_P^ + $ are both larger than
 ${\bar{C}_{Pf}}$ and
 ${\bar{C}_P}$, respectively, thus making η+ to be smaller than η for the same case. The η+ drops with increasing
 $\mathrm{\mathbb{T}}$ for
 $\mathrm{\mathbb{T}} > 1.20$ at 0.30 < StA ≤ 0.45 and for
 $\mathrm{\mathbb{T}} > 1.00$ at StA > 0.45 owing to sufficiently large
 $\bar{C}_{Pi}^ + $.
The wake deflection is not seen for  $\mathrm{\mathbb{T}} = 1.00$ for StA < 0.4 (Godoy-Diana et al. Reference Godoy-Diana, Aider and Wesfreid2008, Reference Godoy-Diana, Marais, Aider and Wesfreid2009; Alam & Muhammad Reference Alam and Muhammad2020). However, the wake deflects for the high StA examined when
 $\mathrm{\mathbb{T}}$ is decreased from 1.00, e.g. at StA = 0.429,
 $\mathrm{\mathbb{T}} = 0.80$; StA = 0.432,
 $0.80 \le \mathrm{\mathbb{T}} < 1.00$. That is, a smaller
 $\mathrm{\mathbb{T}}$ sets off a deflected wake, reducing the distance between two oppositely signed vortices in the near wake. However, a higher
 $\mathrm{\mathbb{T}}$ suppresses the wake deflection, widening the distance between the two oppositely signed vortices in the near wake.
Four swimming regimes are discussed: undesirable  $({C_T} < 0;\;{C_P} > 0)$, floating
 $({C_T} < 0;\;{C_P} < 0)$, normal
 $({C_T} > 0;\;{C_P} > 0)$ and ideal
 $({C_T} > 0;\;{C_P} < 0)$. The undesirable and normal swimming regimes are power hungry (i.e.
 ${C_P} > 0$), while the other two are power generating (i.e.
 ${C_P} < 0$). The forward stroke consists of undesirable, floating and ideal regimes, while the retract stroke consists of normal swimming and some part of the undesirable regime for all
 $\mathrm{\mathbb{T}}$. An increase in
 $\mathrm{\mathbb{T}}$ expands the undesirable and floating regimes, both having
 ${C_T} < 0$, in the forward stroke and hence decreases
 ${\bar{C}_{TF}}$. Although the faster retract stroke with increasing
 $\mathrm{\mathbb{T}}$ does not affect the span of the normal swimming
 $({C_T} > 0)$ and undesirable
 $({C_T} < 0)$ regimes, the magnitude of
 ${C_T}$ does grow rapidly in the normal swimming regime, largely contributed by
 ${\bar{C}_{TR}}$.
The thrust and power response for the kinematics with  $\mathrm{\mathbb{T}} > 1.00$ (e.g.
 $\mathrm{\mathbb{T}} = 1.20$ and 1.40) correspond to fast start locomotion where the largest thrust is generated in-phase with the input power with a high lateral force near the extreme position. The steady swimming gate is connected to sinusoidal pitching
 $(\mathrm{\mathbb{T}} = 1.00)$, where a steady motion of the tail guarantees thrust to sustain steady swimming. A small
 $\mathrm{\mathbb{T}}$ (e.g.
 $\mathrm{\mathbb{T}} = 0.80$) imitates braking locomotion where the power is required to generate drag to stop the forward motion, with
 ${C_T}$ and
 ${C_P}$ being out of phase.
The equations of motion ((2.2)–(2.5)) are implicit and somewhat complicated, which could be simplified and written in an explicit formulation using optimization techniques. It would be interesting to apply the novel asymmetric motion to heaving and heaving + pitching foils.
Funding
The authors wish to acknowledge the support given by the National Natural Science Foundation of China through Grants 12172109, 11672096 and 91752112 and by Research Grant Council of Shenzhen Government through grant JCYJ20180306171921088.
Declaration of interests
The authors report no conflict of interest.
Appendix
A.1. Range of $\mathrm{\mathbb{T}}$

The modified waveform shown in figure 2(c) has slope discontinuities at t = 0, T/2 and T. To make the proposed quasi-symmetric motion continuous and differentiable, we need to make sure that the slope (first derivative) of the motion is continuous at the stroke crossover (i.e. at the end and start of each stroke). To achieve this objective, one could use a blending function to smooth the motion trajectory at each stroke crossover, but the blending function would add additional parameters to the problem. We changed the motion by stretching and contracting the time axis (l′) for a sinusoidal waveform to create the proposed motion without any discontinuity. The idea of compressing / stretching of the time axis follows the curved time–space concept (Wald Reference Wald2010). Equation (2.3) modifies the time by stretching / compressing between intervals (0, 0.5) and (0.5, 1) of t′, which results in a waveform with constant slope at t′ = 0, 0.5 and 1. Although the formulation derived in (2.4) is continuously differentiable, it poses a limit on  $\mathrm{\mathbb{T}}$.
The limitation can be geometrically estimated as shown in figure 24(a), where the first half of the oscillation cycle for  $\mathrm{\mathbb{T}} = 1.0$ is shown as the black line while the constraints of the continuous and constant slope at stroke crossover (i.e. at t′ = 0 and 0.5) are shown with red and green lines. The motion is manipulated by moving the peak, that is at t′ = 0.25 for
 $\mathrm{\mathbb{T}} = 1.0$, to the left or right. Because of the constant slope constraint of ±2
 ${\rm \pi}$ at t′ = 0 and 0.5, respectively, the peak can move only to the extent (t′ = 0.159 and 0.341) shown by the constant slope lines.
The limitation of  $\mathrm{\mathbb{T}}$, shown (a) as a geometrical constraint (red and green lines) posed by slope, (b) as the contour plot of dt′ on the
 $l^{\prime}- \mathrm{\mathbb{T}}$ plane. The constraint positive finite slope (dt′
 $<$ 0) is shown by the dotted region.

The mathematical way of finding the limits is to check for function θ′(t). To be a valid function, there should be only one value of θ′ at a given time t′, i.e. the slope of the function cannot be negative and positive for the forward and retract strokes, respectively. With dt′ positive, the slope is positive in the forward stroke and negative in the retract stroke, i.e. from (2.3),
 \begin{equation}\left. {\begin{array}{*{20}{l}@{}} {\textrm{d}t^{\prime} > 0}\\ {\therefore \dfrac{\textrm{d}}{{\textrm{d}l^{\prime}}}(l^{\prime} + {\textstyle{1 \over 4}}(\mathrm{\mathbb{T}} - 1){{\sin }^2}(2{\rm \pi} l^{\prime})) > 0} \end{array}} \right\},\end{equation}
applying the derivative, the dt′ results in
 \begin{equation}\textrm{d}t^{\prime} = 1 + \frac{{\rm \pi} }{2}(\mathrm{\mathbb{T}} - 1)\sin (4{\rm \pi} l^{\prime}) > 0,\end{equation}
now solving for  $\mathrm{\mathbb{T}}$,
 \begin{equation}(\mathrm{\mathbb{T}} - 1)\sin (4{\rm \pi} l^{\prime}) > - \frac{2}{{\rm \pi} }.\end{equation}
The sin(4 ${\rm \pi}$l′) can be positive as well as negative, thus resulting in two set of inequalities given as
 \begin{equation}\mathrm{\mathbb{T}} > 1 - \frac{2}{{{\rm \pi} \,\sin (4{\rm \pi} l^{\prime})}}\quad \forall \,\sin (4{\rm \pi} l^{\prime}) > 0,\end{equation}
and
 \begin{equation}\mathrm{\mathbb{T}} < 1 - \frac{2}{{{\rm \pi} \,\sin (4{\rm \pi} l^{\prime})}}\quad \forall \,\sin (4{\rm \pi} l^{\prime}) < 0.\end{equation}
The right-hand sides of the inequality solutions ((A4) and (A5)) will maximize and minimize with the sin(4 ${\rm \pi}$l′) value being maximum and minimum, respectively. The maximum and minimum values of the sin(4
 ${\rm \pi}$l′) are 1.0 and −1.0, respectively, which yields the limits
 $\mathrm{\mathbb{T}} > 0.36$ and
 $\mathrm{\mathbb{T}} < 1.64$, respectively. The solutions to the inequalities can also be seen visually in the contour plot of dt′ > 0 on the
 $l^{\prime}- \mathrm{\mathbb{T}}$ plane, as shown in figure 24(b). The dashed lines in figure 24(b) show the limits of
 $\mathrm{\mathbb{T}} = (0.36,1.64)$ within which dt′ > 0. It is worth noting that as the
 $\mathrm{\mathbb{T}}$ approaches its limits, the time resolution to capture the flow would be very high because of extremely large velocities and other problems like cavitation, requiring excessively large
 ${C_P}$ beyond the capacity of the fish or of an autonomous swimming robot.
A.2. StA for swimmers observed in Nature and the optimum efficiency
The optimum StA for swimmers and flyers observed in nature and reported in the literature is 0.2–0.4 (see e.g. Triantafyllou et al. Reference Triantafyllou, Triantafyllou and Grosenbaugh1993; Taylor et al. Reference Taylor, Nudds and Thomas2003). Figure 25(a) presents data collected by Eloy (Reference Eloy2012) from over 40 different sources. It can be seen that as the Rec becomes small, the StA increases. The increase in StA for low Rec can be understood as the need for higher thrust to overcome the relatively larger viscous drag at low Rec.
(a) Graph of StA versus Rec for different swimmers, data collected from various sources and tabulated by Eloy (Reference Eloy2012). (b) Graph of η versus StA for  $\mathrm{\mathbb{T}} = 1.00$.

Figure 25(b) shows the dependence of η on StA for  $\mathrm{\mathbb{T}} = 1.00$ at Rec = 103. A maximum η of 17 % is achieved at StA = 0.63 that is in the natural range of swimmers reported in the literature (figure 25a).



