

1. Introduction
It is often convenient to encode weak categorical or algebraic structures as certain kinds of presheaves on a shape category that models the situation in question, just as we model the homotopy theory of spaces using simplicial sets. For example, the simplicial indexing category
 $\boldsymbol{\Delta}$
is used in
 $(\infty,1)$
-category theory [
Reference Joyal and Tierney40, Reference Lurie45, Reference Rezk52
] and Joyal’s cell category
 $\boldsymbol{\Theta}_n$
is used for
 $(\infty,n)$
-categories [
Reference Ara1, Reference Rezk53
]. For
 $(\infty,1)$
-operads, the Moerdijk–Weiss dendroidal category
 $\boldsymbol{\Omega}$
[
Reference Moerdijk and Weiss48
], which is a category of rooted trees and an enlargement of
 $\boldsymbol{\Delta}$
, underlies several of the many equivalent models [
Reference Barwick3, Reference Chu, Haugseng and Heuts14–Reference Cisinski and Moerdijk17, Reference Heuts, Hinich and Moerdijk36
]. This paper is concerned with shape categories that have been used to model higher versions of certain important types of generalised operads.
The shapes we study will be certain graphs with loose ends (Figure 1), which might come with additional data (e.g. orientations of edges, planar structures) or restrictions (e.g. connected, acyclic). Such graphs are well suited to describing the kinds of operations appearing in generalised operads via the mechanism of ‘graph substitution’ or ‘graph insertion.’ Given two graphs G and H and a bijection between the germs of edges at a vertex of G and the loose ends of H, we can form a new graph
 $G\{H\}$
where a small neighborhood of v has been replaced by H. The categories we focus on have graph substitution built in at a fundamental level, as is the case for several other useful categories involving such graphs (see, for instance, [
Reference Batanin and Markl4, Reference Kaufmann and Ward41
]). However, in this paper we shift attention in our definitions away from graph substitution and towards embeddings of graphs.
The two main graph categories we will discuss are related to modular operads [ Reference Getzler and Kapranov27 ] (also known as compact symmetric multicategories [ Reference Joyal and Kock39 ]), and to wheeled properads [ Reference Markl, Merkulov and Shadrin47 ]. The objects of our shape categories are connected graphs with loose ends, which are undirected in the first case, and directed in the second.
A graph with loose ends.

The graphical category
 $\textbf{U}$
from [
Reference Hackney, Robertson and Yau33
], whose objects are undirected graphs, is intimately connected with modular operads [
Reference Getzler and Kapranov27, Reference Joyal and Kock39
], in that there is an associated nerve theorem (proved in [
Reference Hackney, Robertson and Yau34
], but see also [
Reference Raynor51
]). This theorem says that there is a fully-faithful inclusion of
 $\textbf{ModOp}$
into the category of presheaves
 $\widehat{\textbf{U}} := \textrm{Fun}(\textbf{U}^{\textrm{op}}, \textbf{Set})$
, whose essential image consists of those presheaves satisfying a Segal condition (Definition 6·13). This is the modular operad analogue of the dendroidal nerve theorem from [
Reference Moerdijk and Weiss49, Reference Weber59
]. One can also utilize the category
 $\textbf{U}$
to give notions of
 $(\infty,1)$
-modular operads, as in [
Reference Chu and Haugseng13, Reference Hackney, Robertson and Yau33, Reference Strumila56
]. Our first main theorem is a new description of the graphical category
 $\textbf{U}$
.
Theorem 1 (Theorem 4·15 and Theorem C6). Let G and G′ be undirected connected graphs. A graphical map
 $\varphi \colon G \to G'$
is the same thing as a pair consisting of an involutive function
 $\varphi_0\colon A_G \to A_{G^{\prime}}$
and a function
 $\hat \varphi \colon \operatorname{Emb}\!(G) \to \operatorname{Emb}\!(G')$
, so that this pair is compatible with respect to boundaries and the function
 $\hat \varphi$
preserves unions, vertex disjoint pairs of embeddings, and edges. Composition of graphical maps is given by composition of pairs of functions.
This theorem holds uniformly for maps in both the graphical category
 $\textbf{U}$
and the extended graphical category
 $\widetilde{\textbf{U}}$
from [
Reference Hackney, Robertson and Yau33
]. This has aesthetic appeal, as the previous definitions of these categories relied on separate ad-hoc conditions to prevent ‘collapse.’ A key insight of this paper is the correct notion of unions of embeddings that make this theorem hold, and this appears in Section 3. We will state the precise conditions for the maps appearing in Theorem 1 in Definition 4·2.
One upshot of Theorem 1 is that composition becomes easy, and another is that it makes more transparent the active-inert factorisation system on
 $\textbf{U}$
(see Remark 4·16).
There is a parallel story for directed graphs and wheeled properads. Wheeled properads are a variant of dioperad or polycategory which are capable of modeling both parallel processes and feedback of processes. In [
Reference Hackney, Robertson and Yau29
], the wheeled properadic graphical category was introduced as a category whose morphisms are certain maps between the free wheeled properads generated by directed graphs. As for
 $\textbf{U}$
, there is a nerve theorem for wheeled properads, allowing us to regard
 $\textbf{WPpd}$
as a full subcategory of presheaves on the wheeled properadic graphical category. The following is an analogue of Theorem 1 for directed graphs.
Theorem 1’ (Theorem 5·13 and Theorem C14). Let G and G′ be directed connected graphs. A map
 $\varphi \colon G \to G'$
in the wheeled properadic graphical category is the same thing as a pair consisting of a function
 $\bar\varphi_0\colon E_G \to E_{G^{\prime}}$
and a function
 $\hat \varphi \colon \operatorname{Emb}\!(G) \to \operatorname{Emb}\!(G')$
, so that this pair is compatible with respect to inputs/outputs and the function
 $\hat \varphi$
preserves unions, vertex disjoint pairs of embeddings, and edges. Composition is given by composition of pairs of functions.
This gives a new, purely categorical/combinatorial definition of the wheeled properadic graphical category from [
Reference Hackney, Robertson and Yau29, Reference Hackney, Robertson and Yau31
] which does not rely on the category of wheeled properads. We identify the wheeled properadic graphical category as a comma category
 $\textbf{U}_{/\mathfrak{o}}$
for a certain orientation
 $\textbf{U}$
-presheaf
 $\mathfrak{o}$
.
With this identification, the forgetful functor
 $\textbf{U}_{/\mathfrak{o}} \to \textbf{U}$
becomes relatively easy to understand and analyse. We use this to establish that the adjunction
 $\textbf{WPpd} \rightleftarrows \textbf{ModOp}$
between the categories of wheeled properads and modular operads can be well understood at the presheaf level.
Theorem 2 (Proposition 6·17 and Theorem 6·23). Let
 $f\colon \textbf{U}_{/\mathfrak{o}} \to \textbf{U}$
be the forgetful functor from the category of directed graphs to the category of undirected graphs. At the level of presheaves, both left Kan extension
 \begin{align*}f_! \colon \widehat{\textbf{U}_{/\mathfrak{o}}} \longrightarrow \widehat{\textbf{U}}\end{align*}
and restriction
 \begin{align*}f^* \colon \widehat{\textbf{U}} \longrightarrow \widehat{\textbf{U}_{/\mathfrak{o}}}\end{align*}
preserve Segal objects.
The first part of this theorem is somewhat unusual, and arises from a new, particularly simple formula for the left Kan extension when passing from directed to undirected graphs. We only discovered this formula because of the relationship in the descriptions from Theorem 1 and Theorem 1’.
We are also interested in several graph categories suitable for modeling other operadic structures: dioperads/symmetric polycategories [
Reference Gan23, Reference Garner24
], properads/compact symmetric polycategories [
Reference Duncan21, Reference Vallette57
], and (augmented) cyclic operads/
 $\ast$
-polycategories [
Reference Getzler and Kapranov26, Reference Hinich and Vaintrob37, Reference Shulman55
]. In order to streamline the paper, discussion of these categories is mostly deferred to Appendix A and Appendix B. We also have a third appendix, Appendix C, which addresses the extended (oriented) graphical category, where nodeless loops (that is, vertex-free graphs whose geometric realisation is a circle) are present.
In Appendix A we show how to use Theorem 1 to give a description of categories of simply-connected undirected graphs in a very similar manner to the ‘complete morphisms’ version of the unrooted tree category
 $\boldsymbol{\Xi}$
from [
Reference Hackney, Robertson and Yau32
]. In Appendix B, we show how to identify the properadic graphical category as a subcategory of the wheeled properadic graphical category, and we show that the dioperadic graphical category is a full subcategory of the wheeled properadic graphical category. Finally, in Appendix C, we show that the results of Section 4 and Section 5 also hold when nodeless loops are considered. The results in Appendix C are important, and arguably the ‘correct’ versions of the theorems, but due to the inadequacies of the underlying definitions of graphs themselves they are best treated separately.
A diagram relating the graph categories from this paper appears in Figure 2. The categories in the top right are from Appendix A, the categories on the middle left are in Appendix B, and the two categories on the bottom are in Appendix C.
Functors between graph categories.

Further directions
One motivation for this work is the hope that an alternative definition of the graph categories could help facilitate comparisons to other, related graph categories in the literature. Of special interest are the operadic categories of graphs appearing in [ Reference Batanin and Markl4–Reference Batanin, Markl and Obradović6 ], which should be closely related to subcategories of active maps by [ Reference Berger9 , proposition 3·2]. We are also interested in the apparent differences with the graph categories arising from a twisted arrow construction in [ Reference Burkin10 ].
Another motivation is to provide a blueprint for work on operadic structures based on disconnected graphs. Such operadic structures include props, wheeled props, and non-connected modular operads. We expect that the definitions in this paper generalise to yield plausible graph categories for these three structures, once the appropriate notion of embedding is established. Moreover, the active-inert factorisation systems on these categories, which are used to formulate the Segal condition, should arise in a natural and transparent way (see Remark 4·16). This would all play a role in developments related to [ Reference Raynor50 ], which concerns the circuit algebras of Bar–Natan and Dansco [ Reference Bar-Natan and Dancso2 ]. These circuit algebras are a generalisation of the planar algebras of Jones [ Reference Jones38 ], and turn out to be the same thing as wheeled props [ Reference Dancso, Halacheva and Robertson18 ]. In addition, it would be interesting to compare the kinds of infinity-props arising from this Segal condition with those appearing in [ Reference Haugseng and Kock35 ].
Lastly, the reader will notice that we have almost entirely avoided any homotopical issues, but these should be addressed later. We would like to know how the formulas for left Kan extensions in Section 6·1 behave with respect to Quillen model structures for higher operadic structures. Can the formula from Remark 6·21 be leveraged to resolve [
Reference Drummond-Cole and Hackney20
, remark 6·8], which seems to be needed for a conditional result of Walde [
Reference Walde58
, remark 5·0·20]? It would also be interesting to know if Theorem 2 can be promoted to the
 $\infty$
-categories of Segal objects in spaces from [
Reference Chu and Haugseng13
], and also to the enriched context following [
Reference Chu and Haugseng12, Reference Gepner and Haugseng25
].
Structure of the paper
Section 2 mostly contains preliminary material which has previously appeared elsewhere. Section 3 contains a definition of unions of embeddings, but only Definition 3·1 and Example 3·2 are needed for the main narrative of the paper; the rest of the section is examining questions of existence of unions and may be skipped. Section 4 introduces the new description of graphical maps at the beginning, and the remainder of the section is devoted to the proof of Theorem 1.
Directed graphs appear in Section 5, and the new definition of the wheeled properadic graphical category appears as Definition 5·8 and Proposition 5·10. A reader who is not already familiar with wheeled properads and the wheeled properadic graphical category may wish to stop reading this section after Remark 5·12 (to skip the proof of Theorem 1’).
The final section of the main narrative of the paper is Section 6, which turns its attention to Segal presheaves which (via nerve theorems of the author, Robertson and Yau) are the same thing as modular operads and wheeled properads, respectively. Theorem 2 is proved in Section 6·1. Section 6 also deals with several other graph categories from the appendices, though relatively little knowledge is needed about them to follow this. It is not necessary to read the appendices to understand most of this section.
The paper contains three appendices, which are largely independent and may be read or skipped based on the interest of the reader. Appendix A is about a characterisation of maps in categories of undirected trees, and can be read at any point after Section 4. Appendix B exhibits the properadic graphical category as a particular non-full subcategory of
 $\textbf{U}_{/\mathfrak{o}}$
whose objects are acyclic directed graphs, and can be tackled after Proposition 5·10. Finally, Appendix C is about the ‘extended’ versions of graphical categories that include the nodeless loop as an object. The first part can be read after Section 4, whereas Appendix C·1 relies on Section 5·2.
2. Preliminaries
The purpose of this section is to recall the most essential information about the graphical category
 $\textbf{U}$
from [
Reference Hackney, Robertson and Yau33
]. The following definition of a combinatorial model for ‘graphs with loose ends’ is due to Joyal and Kock, and appears in [
Reference Joyal and Kock39
, section 3] under the name Feynman graphs.
Definition 2·1 (Graphs). Write
 $\mathscr{I}$
for the category freely generated by the graph

subject to the relation that the nontrivial endomorphism of
 $\texttt{a}$
squares to the identity.
-
(i) A graph is a functor
 $\mathscr{I} \to \textbf{FinSet}$
so that the self-map of
$\texttt{a}$
goes to a fixpoint-free involution and the generating map
$\texttt{a} \leftarrow \texttt{d}$
goes to a monomorphism.


A graph G will be written as

and we usually behave as though the leftward arrow is a subset inclusion
 $D_G \subseteq A_G$
.
-
(ii) If
$v\in V_G$
is a vertex, then we write
$nb(v) := t^{-1}(v) \subseteq D_G$
for the neighbourhood of v. -
(iii) The boundary of a graph G is the set
$\eth(G) = A_G \setminus D_G$
. -
(iv) The set of edges
is the set of
\begin{align*} E_G = \{ [a,a^\dagger] \mid a \in A_G\} \cong A_G / {\sim}\end{align*}
$\dagger$
-orbits, and has half the cardinality of
$A_G$
.
-
(v) An edge
$[a,a^\dagger]$
is an internal edge if neither of
$a,a^\dagger$
are elements of
$\eth(G)$
, otherwise it is a boundary edge.


In Appendix C we will use a more general (but also more fiddly) version of graph [ Reference Hackney, Robertson and Yau33 , definition 4·1], where the boundary is additional specified data.
An embedding
 ${\unicode{x2606}}_5 \rightarrowtail G$
.

Example 2·2. We give two basic examples of graphs that we will use repeatedly (see [ Reference Hackney, Robertson and Yau33 , example 1·4]).
-
(i) We write
$G = {{\updownarrow}}$
for the edge, which has exactly two arcs
$A_G = \{ \sharp, \flat \}$
, and
$D_G = \varnothing = V_G$
. Note that
$\eth(G) = A_G$
. -
(ii) If
$n\geq 0$
, we write
$G = {\unicode{x2606}}_n$
for the
n
-star. This graph has
$V_G$
a one-point set,
$D_G = \{1, \dots, n \}$
, and
$A_G = \{ 1, 1^\dagger, \dots, n, n^\dagger \}$
. Note that
$\eth(G) = \{ 1^\dagger, \dots, n^\dagger \}$
. The 5-star is depicted on the left of Figure 3.


From a graph G, one can obtain a topological space as a quotient space of
 \begin{align*} V_G \amalg \left( \coprod_{D_G} [0,{\textstyle\frac{2}{3}}) \right) \amalg \left( \coprod_{\eth(G)} (0,{\textstyle\frac{2}{3}}) \right) \end{align*}
by identifying,
 $x \sim 1-x$
where
 $x\in ({1}/{3},{2}/{3})$
is in the a-component and
 $1-x\in ({1}/{3},{2}/{3})$
is in the
 $a^\dagger$
-component, and letting t identify 0 in the d-component with
 $t(d) \in V_G$
. As vertices may have arity two, in order to not lose any information one should consider this as a pair of spaces
 $\mathscr{X} = (X,V)$
with V finite. Notice that we can recover all of the data of G from the homeomorphism class of
 $\mathscr{X}$
(see [
Reference Hackney, Robertson and Yau33
, section 1]).
The following definition of étale map appeared in [ Reference Joyal and Kock39 ]; these are the maps of graphs which preserve arity of vertices.
Definition 2·3. An étale map between graphs is a natural transformation of functors

so that the right-hand square is a pullback. An embedding between connected graphs is an étale map which is injective on vertices.
‘Connected’ in the preceding definition means in the usual sense for an object in
 $\textbf{FinSet}^{\mathscr{I}}$
, namely G is connected if and only if given any coproduct splitting
 $G \cong G_1 \amalg G_2$
precisely one of
 $G_1$
or
 $G_2$
is empty. This is equivalent to G being non-empty and every two elements have a path between them (see Definition A1), and is also equivalent to the associated topological space being connected.
Étale maps from the edge
 ${\updownarrow}$
classify arcs, as they are determined by where
 $\sharp$
is sent. Étale maps from stars weakly classify vertices: if nb(v) has cardinality n, then there are precisely
 $n!$
étale maps
 ${\unicode{x2606}}_n \to G$
which send the unique vertex to v. See also Example 2·5.
Remark 2·4. Each étale map
 $G\to G'$
induces a local homeomorphism
 $\mathscr{X} \to \mathscr{X}'$
of the corresponding topological graphs, and each embedding between connected graphs induces an injective local homeomorphism. If we insist that we can recover the original étale map from the local homeomorphism, then this local homeomorphism is essentially unique up to deformation through a family of local homeomorphisms. In contrast, there are two distinct (orientation-preserving) embeddings
 $(0,1) \amalg (0,1) \to (0,1)$
up to deformation through families of embeddings, while there is only one when considered up to deformation through families of local homeomorphisms. This hints at why étale maps may be ill-suited for describing embeddings with disconnected domain.
Example 2·5 (Examples of embeddings). If G is a graph, then every edge and every vertex determines an embedding.
-
(i) Suppose that
$e = [a,a^\dagger]$
is an edge of G. We can define a graph, denoted
${\updownarrow}_e$
, with
$V = D = \varnothing$
, and
$A = \eth({\updownarrow}_e) = \{a,a^\dagger\}$
together with the unique fixpoint-free involution. Inclusion of arc sets yields a canonical embedding
${{\updownarrow}}_e \rightarrowtail G$
. -
(ii) If
$f \colon H \rightarrowtail G$
is any embedding with H isomorphic to
${\updownarrow}$
(which happens if and only if
$V_H = \varnothing$
), we say that f is an edge. Such an f will be isomorphic to one of the inclusions
${{\updownarrow}}_e \rightarrowtail G$
. -
(iii) Suppose v is a vertex of G. Define
${\unicode{x2606}}_v$
to be the graph with
$V_{{\unicode{x2606}}_v} = \{ v \}$
,
$D_{{\unicode{x2606}}_v} = nb(v) = \{d_1, \dots, d_n \} \subseteq D_G$
,
$\eth({\unicode{x2606}}_v) = \{b_1, \dots, b_n\}$
(which are new, formally defined elements), and
$d_i^\dagger := b_i$
. Then
${\unicode{x2606}}_v$
is isomorphic to
${\unicode{x2606}}_n$
, and there is an embedding
$\iota_v \colon {\unicode{x2606}}_v \rightarrowtail G$
which sends
$d_i$
to
$d_i \in D_G$
and
$b_i$
to
$d_i^\dagger \in A_G$
. -
(iv) It is not necessary for an embedding to be injective on arcs. As an example, take the quotient G of
${\unicode{x2606}}_5$
(see Example 2·2) by identifying the arcs
$2 \sim 5^\dagger$
and
$2^\dagger \sim 5$
but keeping the rest of the structure the same. This is depicted in Figure 3. The canonical map
${\unicode{x2606}}_5 \rightarrowtail G$
is an embedding but not a monomorphism. Likewise, if v is an arbitrary vertex of a graph G, then
$\iota_v \colon {\unicode{x2606}}_v \rightarrowtail G$
is injective on arcs if and only if there are no loop edges at v.


This last point essentially indicates the only way an embedding can fail to be a monomorphism on arcs and edges — by identifying pairs of boundary edges (Lemma 2·14). Another example appears in Figure 4 below.
Each of
 $\ell_1$
,
 $\ell_2$
, and
 $id_G$
is a union (Definition 3·1) for h and k.

Lemma 2·6.
If
 $f \colon H \rightarrowtail G$
is an embedding and
 $H\cong G$
, then f is an isomorphism.
Proof. The map f provides injections of finite sets
 $D_H \hookrightarrow D_G$
and
 $V_H \hookrightarrow V_G$
which must be isomorphisms. To show that
 $A_H \to A_G$
is an injection (and hence an isomorphism), it is enough to show that the injection
 $\eth(H) \to A_G$
lands in
 $\eth(G)$
. This is clear if G is an edge, since then
 $A_G = \eth(G)$
. Assume that G is not an edge. Given
 $a\in \eth(G)$
, we know
 $a^\dagger \in D_G$
, so
 $a^\dagger = f(d)$
for some unique
 $d\in D_H$
. Notice that
 $d^\dagger \in \eth(H)$
, for otherwise
 $a = f(d^\dagger)$
would be an element of
 $D_G$
. This shows that
 $f(\eth(H)) \subseteq \eth(G)$
as desired, so
 $f \colon A_H \to A_G$
is an isomorphism.
In definition 1·28 of [
Reference Hackney, Robertson and Yau33
], a set
 $\operatorname{Emb}\!(G)$
is defined by considering all embeddings with codomain G, and then identifying isomorphic embeddings. That is,
 $f\sim h$
just when there exists a (unique) isomorphism z with
 $f=hz$
. We next give an alternative definition of this set which reveals additional structure.
Given a (small) category
 $\textbf{C}$
, the posetal reflection of
 $\textbf{C}$
is obtained by identifying objects
 $c_0$
and
 $c_1$
if and only if there are arrows
 $c_0 \to c_1$
and
 $c_1 \to c_0$
in
 $\textbf{C}$
, and declaring that on equivalence classes
 $[c] \leq [c']$
just when there is an arrow
 $c \to c'$
in
 $\textbf{C}$
.
Proposition 2·7.
Let
 $\acute{\textbf{E}}$
be the category of graphs and étale maps between them, let G be a connected graph, and let
 $\textbf{C} \subseteq \acute{\textbf{E}}_{/G}$
be the full subcategory of the slice on the embeddings with codomain G. Then
 $\operatorname{Emb}\!(G)$
is the underlying set of the posetal reflection of (a skeleton of)
 $\textbf{C}$
.
Proof. First, notice that for a morphism

from h to k, we have that the étale map f is an embedding. Suppose that we have two morphisms f and g of
 $\textbf{C}$

then
 $gf \colon H \to H$
is an isomorphism by Lemma 2·6. Likewise,
 $fg \colon K \to K$
is an isomorphism. Since fg and gf are isomorphisms, we conclude that f is an isomorphism and hence
 $[h]=[k]$
in
 $\operatorname{Emb}\!(G)$
.
If
 $h = kz$
for some isomorphism z, then h and k are identified in the posetal reflection.
In order to give the definition of the graphical category
 $\textbf{U}$
, we first need some notation.
Definition 2·8 (Boundary and vertex sum of embeddings). If S is a set, write
 $\wp(S)$
for the power set, that is, for the set whose elements are the subsets of S. Let
 $\mathbb{N}S$
denote the free commutative monoid on S, whose elements are finite unordered lists of elements of S. When S is finite, regard
 $\wp(S)$
as the subset of
 $\mathbb{N}S$
containing those lists which do not have repeated elements. Now suppose G is a graph.
-
(i) Write
$\varsigma \colon \operatorname{Emb}\!(G) \to \mathbb{N}V_G$
for the map of sets which sends the class of an embedding
$f\colon H \rightarrowtail G$
to
$\varsigma[f] = \sum_{v\in V_H} f(v) \in \mathbb{N}V_G$
. As embeddings are injective on vertices, this comes from a function
$\varsigma \colon \operatorname{Emb}\!(G) \to \wp(V_G)$
sending [f] to
$f(V_H)$
. -
(ii) Write
$\eth \colon \operatorname{Emb}\!(G) \to \wp(A_G) \subseteq \mathbb{N}A_G$
for the map which sends the class of an embedding
$f \colon H \rightarrowtail G$
to
$\eth([f]) = f(\eth(H)) \subseteq A_G$
.


By [
Reference Hackney, Robertson and Yau33
, lemma 1·20],
 $\eth(H) \to A_G$
is injective, so
 $\eth([f])$
is isomorphic to
 $\eth(H)$
and may be written as
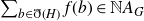 $\sum_{b\in \eth(H)} f(b) \in \mathbb{N}A_G$
. See Section 2·1 below for more on embeddings. The following appears as definition 1·31 of [
Reference Hackney, Robertson and Yau33
].
Definition 2·9 (Graphical map). Let G and G
′ be connected (undirected) graphs. A graphical map
 $\varphi \colon G \to G'$
is a pair
 $(\varphi_0, \varphi_1)$
consisting of an involutive function
 $\varphi_0 \colon A_G \to A_{G^{\prime}}$
and a function
 $\varphi_1 \colon V_G \to \operatorname{Emb}\!(G')$
, so that:
-
(i) the inequality
holds in
\begin{align*} \sum_{v\in V_G} \varsigma(\varphi_1(v)) \leq \sum_{w\in V_{G^{\prime}}} w\end{align*}
$\mathbb{N}V_{G^{\prime}}$
(i.e.,
$\sum \varsigma(\varphi_1(v)) \in \wp(V_{G^{\prime}})$
);
-
(ii) for each
$v \in V_G$
, there is a bijection making the diagramcommute;
-
(iii) if
$\eth(G)$
is empty, then there exists
$v \in V_G$
so that
$\varphi_1(v)$
is not an edge.


Connected graphs and graphical maps form a category denoted by
 $\textbf{U}$
. The composition, which we will rarely need to deal with explicitly, appears in definition 1·44 of [
Reference Hackney, Robertson and Yau33
]. See the second paragraph of Remark 2·13 below for a description that will be used in the proof of Lemma 4·11. The purpose of condition (iii) is to avoid the situation where graph substitution would result in a nodeless loop (Example C2).
Definition 2·10 (Inert and active maps). Let H, G, G ′ be connected graphs.
-
(i) If
$f\colon H \rightarrowtail G$
is an embedding, then there is an associated graphical map
$H \to G$
whose action on arcs agrees with f and whose action on vertices is given by the composite We often also call such a map inert and write
\begin{align*} V_H \xrightarrow{f} V_G \hookrightarrow \operatorname{Emb}\!(G).\end{align*}
$\textbf{U}_{\textrm{int}} \subset \textbf{U}$
for the wide subcategory consisting of the inert maps. (In [
Reference Hackney, Robertson and Yau33, Reference Hackney, Robertson and Yau34
] this category was denoted by
$\textbf{U}_{\textrm{emb}}$
.)
-
(ii) A graphical map
$\varphi \colon G \to G'$
is called active if
$\varphi_0$
induces a bijectionbetween boundary sets. We write
$\textbf{U}_{\textrm{act}} \subset \textbf{U}$
for the wide subcategory consisting of all of the active maps, and we use the notation
.


Example 2·11. If G is a graph and
 $\eth(G)$
has cardinality n, then there are
 $n!$
different active maps
 , and these are determined solely by a choice of bijection
 $\eth({\unicode{x2606}}_n) \cong \eth(G)$
. Given any two such active maps
 , there is a unique automorphism z of
 ${\unicode{x2606}}_n$
with
 $\alpha' z = \alpha$
.
The following is theorem 2·15 of [ Reference Hackney, Robertson and Yau33 ].
Proposition 2·12.
The pair
 $(\textbf{U}_{\textrm{act}},\textbf{U}_{\textrm{int}})$
is an orthogonal factorisation system on
 $\textbf{U}$
. That is, both subcategories contain all isomorphisms, every graphical map
 $\varphi \colon G \to G'$
factors as an active map followed by an embedding

and this factorisation is unique up to unique isomorphism.
Remark 2·13. If
 $\varphi \colon G \to G'$
is a graphical map and
 $\varphi_v \colon H_v \rightarrowtail G'$
represents
 $\varphi_1(v)$
, condition (ii) of Definition 2·9 provides a bijection between nb(v) and
 $\eth(H_v)\cong \eth(\varphi_1(v))$
. This is the data necessary to construct the graph substitution
 $G\{H_v\}$
(see, for instance, [
Reference Yau and Johnson61
, chapter 5], [
Reference Hackney, Robertson and Yau33
, section 1·2], and [
Reference Batanin and Berger7
, section 13]). Condition (iii) is included to guarantee that
 $G\{H_v\}$
is not a nodeless loop, while condition (i) ensures that there is an injection
 $V_{G\{H_v\}} \cong \amalg V_{H_v} \hookrightarrow V_{G^{\prime}}$
. This graph substitution comes equipped with an embedding
 $G\{H_v\} \rightarrowtail G'$
canonically factoring all of the embeddings
 $\varphi_v \colon H_v \rightarrowtail G'$
, and we can take
 $K= G\{H_v\}$
in the factorisation from Proposition 2·12.
Composition of graphical maps was formulated in [
Reference Hackney, Robertson and Yau33
, definition 1·44] by first defining precomposition with inert maps, and then utilising the above graph substitutions. This means that if
 $\psi \colon G' \to G''$
is another graphical map and
 $v\in V_G$
, then
 $(\psi \circ \varphi)_1(v) \in \operatorname{Emb}\!(G'')$
is represented by the right vertical embedding in the diagram below.

2·1. Lemmas concerning embeddings
We now give three lemmas governing the behavior of embeddings which will be useful several times in this paper. The first appears as lemma 1·22 of [
Reference Hackney, Robertson and Yau33
], and the reader should note that it is not possible to have
 $i=j$
.
Lemma 2·14.
Suppose
 $f \colon G \rightarrowtail G'$
is an embedding and
 $a_1\neq a_2$
are distinct arcs of G with
 $f(a_1) = f(a_2)$
. Then there are indices
 $i,j \in \{1,2\}$
so that
 $a_i, a_j^\dagger \in \eth(G)$
and
 $a_i^\dagger, a_j \in D_G$
.
The second, which appears as proposition 1·25 of [ Reference Hackney, Robertson and Yau33 ], says that embeddings are nearly determined by their boundary, up to some ambiguity about whether or not they contain a vertex.
Lemma 2·15.
Let G be a connected graph, and
 $E_G \hookrightarrow \operatorname{Emb}\!(G)$
be the inclusion of edges into embeddings from Example 2·5. Then the composites
 \begin{align*}E_G \hookrightarrow \operatorname{Emb}\!(G) & \xrightarrow{\eth} \mathbb{N}A_G \\[5pt] \operatorname{Emb}\!(G) \setminus E_G \hookrightarrow \operatorname{Emb}\!(G) & \xrightarrow{\eth} \mathbb{N}A_G\end{align*}
are injective.
The third is a generalisation of lemma 1·26 of [ Reference Hackney, Robertson and Yau33 ], which says that an embedding whose domain has empty boundary must be an isomorphism.
Lemma 2·16
If
 $f \colon H \rightarrowtail G$
is an embedding and
 $\eth(f) \subseteq \eth(G)$
, then f is an isomorphism. In particular, f must be an isomorphism if
 $\eth(H) = \varnothing$
.
Proof. If H is an edge, then
 $\eth(G)$
contains a pair
 $\{a,a^\dagger\} = \eth(f)$
. Since G is connected, it must be an edge as well.
Now suppose
 $V_H$
is inhabited. The argument from the proof of [
Reference Hackney, Robertson and Yau33
, lemma 1·26] shows that
 $V_H \to V_G$
is surjective, hence a bijection. Since f is étale,
 $D_H \to D_G$
is an isomorphism as well. If there were an element
 $a\in \eth(G) \setminus \eth(f)$
, then since G is not an edge we would have
 $a^\dagger \in D_G$
, hence
 $a^\dagger = f(d)$
for some (unique)
 $d\in D_H$
. But then
 $f(d^\dagger) = a \in \eth(G)$
, and only elements of
 $\eth(H)$
can map to elements of
 $\eth(G)$
, so
 $d^\dagger \in \eth(H)$
. This contradicts the assumption on a. It follows that
 $\eth(H) \hookrightarrow \eth(G)$
is also surjective, hence
 $A_H \to A_G$
is an isomorphism.
3. Unions of embeddings
In this section we consider a notion of unions of embeddings into a graph G. Despite the fact that
 $\operatorname{Emb}\!(G)$
is a poset, it is not particularly well-behaved, and our notion has little to do with any joins that happen to exist. As an example, the embeddings h and k in Figure 4 do not have a least upper bound, since the domain of such would necessarily be disconnected. Even when a least upper bound exists, it may be too big to be a union (see the paragraph following proposition 2·2·8 of [
Reference Chu and Hackney11
] for one example). See also Example 4·6.
Definition 3·1. Suppose that
 $h\colon H \rightarrowtail G$
and
 $k\colon K \rightarrowtail G$
are two embeddings. An embedding
 $\ell \colon L \rightarrowtail G$
is called a union of
h
and
k
if:
-
(1)
$[\ell]$
is an upper bound for both [h] and [k] in the poset
$\operatorname{Emb}\!(G)$
(that is, there is a factorisation
$H \rightarrowtail L \rightarrowtail G$
of h and likewise for k); and -
(2)
$\ell (V_L) = h(V_H) \cup k(V_K)$
.


Unions in this sense are frequently not unique, as we can see in Figure 4.
Example 3·2. If
 $[h] \leq [k]$
in the poset
 $\operatorname{Emb}\!(G)$
, then k is a union of h and k.
We now show that if two embeddings have any intersection at all, then they have at least one union.
Proposition 3·3.
Suppose
 $h\colon H \rightarrowtail G$
and
 $k\colon K \rightarrowtail G$
are embeddings. If either
 $h(A_H) \cap k(A_K)$
or
 $h(V_H) \cap k(V_K)$
is inhabited, then there exists at least one union
 $\ell \colon L \rightarrowtail G$
of h and k.
This proposition follows from Lemma 3·4 and Lemma 3·5 below. It is useful if one wishes to directly construct the active-inert factorisations from Proposition 2·12 using only the description of graphical maps from Definition 4·2. Existence of unions isn’t strictly necessary for the rest of this paper, and we recommend skipping ahead to Section 4 on first reading.
Suppose we have two embeddings
 $h\colon H \rightarrowtail G$
and
 $k\colon K \rightarrowtail G$
. We can form the pullback

in the category
 $\textbf{FinSet}^{\mathscr{I}}$
. The object J will still be a graph, though in general it does not need to be connected. In fact, since embeddings are not always monomorphisms, we may have that J is not connected even when
 $h=k$
. See Example 3·6 below.
Lemma 3·4.
Suppose h and k are embeddings. Form an object
 $L\in \textbf{FinSet}^{\mathscr{I}}$
by taking a pullback followed by a pushout.

The object L is a graph.
Proof. Consider the map
 $\ell$
induced by the pushout property:

First note that the involution on
 $A_L$
does not have a fixed point: suppose, to the contrary, that
 $a\in A_L$
satisfies
 $a = a^\dagger$
. Then
 $\ell(a) = \ell(a^\dagger) = \ell(a)^\dagger$
, implying that
 $\ell(a)$
is a fixed point of
 $A_G$
, a contradiction.
It remains to show that
 $D_L \to A_L$
is injective. But this map fits into the diagram

Since
 $D_H \to D_G$
and
 $D_K\to D_G$
are injective and
 $D_J$
is
 $D_H \times_{D_G} D_K$
, the left vertical map is injective. The bottom map is injective because G is a graph, hence the top map is injective as well.
Lemma 3·5. Consider the diagram

from the previous lemma. If J is inhabited, then L is connected and f,g, and
 $\ell$
are embeddings.
Proof. Suppose J contains an arc or a vertex, classified by an étale map
 $E \to J$
from
 $E = {\updownarrow}$
or
 $E = {\unicode{x2606}}_n$
. If L splits as a coproduct
 $L = L_1 \amalg L_2$
, then since H and K are connected, f factors through exactly one
 $L_i$
and g factors through exactly one
 $L_j$
. Since both of these factor the composition
 $E \to J \to L$
and E is connected, we have
 $i=j$
and hence the other term is empty. Thus L is connected.
We next show that
 $\ell$
is an embedding. We have
 $V_J \cong V_H \times_{V_G} V_K \cong h(V_H) \cap k(V_K)$
, so
 $V_L = V_H \amalg_{V_J} V_K$
maps monomorphically to
 $h(V_H) \cup k(V_K) \subseteq V_G$
. Similarly, we have
 $D_L \cong h(D_H) \cup k(D_K)$
. As h and k are embeddings, the bottom square in the diagram

is a pullback, hence
 $\ell$
is an embedding. Using the pasting law for pullbacks and the fact that
 $\ell$
and h are embeddings, the top square is also a pullback, hence f is an embedding. A similar proof shows g is an embedding.
The construction from Lemma 3·4 produces a union from embeddings h and k which intersect, but it may not be the one you’d expect. For example, even when
 $h=k$
it may be that
 $[\ell]$
is strictly larger than [h].
Example 3·6. Suppose that
 $h=k \colon H=K={\unicode{x2606}}_2 \rightarrowtail G$
picks out the vertex in the loop with one vertex (see Figure 5). One can compute that the pullback J has
 \begin{align*} A_J = \{ (1,1), (1^\dagger,1^\dagger), (2,2), (2^\dagger, 2^\dagger), (1,2^\dagger), (1^\dagger,2), (2^\dagger,1), (2,1^\dagger) \}\end{align*}
while
 $D_J = \{1,2\}$
and
 $V_J = \{ \bullet \}$
. It follows that
 $\ell \colon L \rightarrowtail G$
is an isomorphism, hence
 $[h] < [id_G] = [\ell]$
.
The embedding
 $h=k \colon {\unicode{x2606}}_2 \rightarrowtail G$
from Example 3·6.

4. A new description of graphical maps
In this section we give an alternative definition of graphical map as a pair of functions with certain properties, which makes composition transparent. These new maps encode the same data as those from Definition 2·9, but encode it in a different way. After presenting the definition, we spend the remainder of the section showing how to go back and forth between the two descriptions, and finally give the equivalence in Theorem 4·15.
Definition 4·1. Two embeddings
 $h \colon H \rightarrowtail G$
and
 $k \colon K \rightarrowtail G$
are said to be vertex disjoint if
 $h(V_H) \cap k(V_K) \subseteq V_G$
is empty. In this case we also say the pair
 $[h],[k]\in \operatorname{Emb}\!(G)$
is vertex disjoint, and we note that this property does not depend on a choice of representatives.
Definition 4·2. Let G and G
′ be connected graphs. A new graph map
 $\varphi \colon G \to G'$
is a pair
 $(\varphi_0, \hat \varphi)$
consisting of an involutive function
 $\varphi_0 \colon A_G \to A_{G^{\prime}}$
and a function
 $\hat \varphi \colon \operatorname{Emb}\!(G) \to \operatorname{Emb}\!(G')$
, so that:
-
(i) the function
$\hat \varphi$
sends edges to edges; -
(ii) the function
$\hat \varphi$
preserves unions: if
$[\ell]$
is a union of [h] and [k] in
$\operatorname{Emb}\!(G)$
, then
$\hat \varphi[\ell]$
is a union of
$\hat \varphi[h]$
and
$\hat \varphi[k]$
in
$\operatorname{Emb}\!(G')$
; -
(iii) the function
$\hat \varphi$
takes vertex disjoint pairs to vertex disjoint pairs; -
(iv) the diagram
commutes.


Composition of new graph maps is given by composition of the two constituent functions.
Remark 4·3. Condition (iv) is equivalent to insisting that, for each
 $[h] \in \operatorname{Emb}\!(G)$
, there is a (necessarily unique) bijection as displayed to the left:

By Example 3·2, condition (ii) in particular implies that
 $\hat \varphi \colon \operatorname{Emb}\!(G) \to \operatorname{Emb}\!(G')$
preserves the partial order. Notice that condition (i) is nearly the same as asking that
 $\hat \varphi$
preserves minimal elements: indeed, for almost all connected graphs G, the set of edges coincides with the set of minimal elements of
 $\operatorname{Emb}\!(G)$
. The lone exception is the case when
 $G = {\unicode{x2606}}_0$
is an isolated vertex, which has no edges –
 $\operatorname{Emb}\!({\unicode{x2606}}_0)$
has a unique element, and Lemma 2·16 implies that this element maps to the maximal element of
 $\operatorname{Emb}\!(G')$
.
Our aim in this section is to show that new graph maps are equivalent to graphical maps from Definition 2·9. This work culminates in Theorem 4·15, which shows that the following two constructions are inverses.
Construction 4·4. Given a new graph map
 $\varphi \colon G \to G'$
, we obtain the composite

We write
 $\mathfrak{O}$
for the assignment that takes a new graph map
 $\varphi = (\varphi_0, \hat \varphi)$
and produces the pair
 $\mathfrak{O} \varphi := (\varphi_0, \varphi_1)$
.
Construction 4·5. Suppose that
 $\varphi = (\varphi_0, \varphi_1) \colon G \to G'$
is a graphical map. Define a function
 \begin{align*} \hat \varphi \colon \operatorname{Emb}\!(G) \longrightarrow \operatorname{Emb}\!(G')\end{align*}
by declaring that
 $\hat \varphi [f] := [g]$
, where g sits inside the active-inert factorisation of
 $\varphi \circ f$
from Proposition 2·12:

As we are working with an orthogonal factorisation system, the element [g] does not depend on the choice of representative for [f] or the chosen factorisation. We write
 $\mathfrak{N}$
for the assignment that takes a graphical map
 $\varphi = (\varphi_0, \varphi_1)$
and produces the pair
 $\mathfrak{N} \varphi := (\varphi_0, \hat \varphi)$
.
With this construction in hand, we give an example to show that graphical maps do not preserve least upper bounds of embeddings.
Example 4·6. Consider the graphs G (on the left) and G
′ (on the right) of Figure 6, and let
 $\varphi \colon G \to G'$
be the embedding. Now
 $\iota_v \colon {\unicode{x2606}}_v \rightarrowtail G$
and
 $\iota_w \colon {\unicode{x2606}}_w \rightarrowtail G$
have a least upper bound, namely
 $id_G$
. But
 \begin{align*} \hat\varphi [\iota_v] &= [\iota_v \colon {\unicode{x2606}}_v \to G'] \\[5pt] \hat\varphi [\iota_w] &= [\iota_w \colon {\unicode{x2606}}_w \to G'] \\[5pt] \hat\varphi [id_G] &= [\varphi \colon G \to G'].\end{align*}
The element
 $\hat\varphi [id_G] = [\varphi]$
is not the least upper bound for the two star inclusions in G
′. Indeed, by snipping the edge
 $e_1$
in G
′ we obtain another embedding which factors the two star inclusions, but which does not factor
 $\varphi$
. (As in Figure 4, the least upper bound does not exist.)
Graphs G and G′.

4·1. From new graph maps to graphical maps
Our aim in this section is to show that
 $\mathfrak{O}$
takes new graph maps to graphical maps.
Theorem 4·7.
If
 $\varphi = (\varphi_0, \hat \varphi)$
is a new graph map, then
 $\mathfrak{O}\varphi = (\varphi_0,\varphi_1)$
is a graphical map in the sense of Definition 2·9.
The following statement involves the vertex sum function
 $\varsigma \colon \operatorname{Emb}\!(G) \to \mathbb{N}V_G$
from Definition 2·8.
Lemma 4·8. Given a diagram of embeddings,

we have
 \begin{equation}\varsigma[\ell] \geq \varsigma[h] + \varsigma[k] - \sum_{v\in f(V_H) \cap g(V_K)} \ell(v)\end{equation}
in
 $\mathbb{N}V_G$
. Equality holds if and only if
 $\ell$
is a union of h and k. If h and k are vertex disjoint and
 $\ell$
is a union of h and k, then
 $\varsigma[\ell] = \varsigma[h] + \varsigma[k]$
.
Proof. We compute, using that embeddings are injective on vertices:
 \begin{align*}\varsigma[h] + \varsigma[k] &= \sum_{u\in V_H} h(u) + \sum_{w\in V_K} k(w) = \sum_{u^{\prime}\in f(V_H)} \ell(u^{\prime}) + \sum_{w^{\prime}\in g(V_K)} \ell(w^{\prime}) \\[5pt] &= \sum_{v\in f(V_H) \cup g(V_K)} \ell(v) + \sum_{v\in f(V_H) \cap g(V_K)} \ell(v) \leq \varsigma[\ell] + \sum_{v\in f(V_H) \cap g(V_K)} \ell(v).\end{align*}
The last inequality is an equality if and only if
 $f(V_H) \cup g(V_K) = V_L$
, that is, if and only if
 $\ell$
is a union of h and k. If h and k are vertex disjoint then
 $f(V_H) \cap g(V_K)$
is empty, so the final statement holds.
Lemma 4·9.
Given an embedding
 $\ell \colon L \rightarrowtail G$
where L has an internal edge, there exists a vertex
 $v \in L$
and an embedding
 $g \colon K \rightarrowtail L$
with
 $g(V_K) = V_L \setminus \{v\}$
. In particular,
 $\ell$
is a union of
 $h = \ell \iota_v \colon {\unicode{x2606}}_v \rightarrowtail G$
and
 $k = \ell g \colon K \rightarrowtail G$
.
Proof. If L has only a single vertex v, then since L contains an edge, we can form

where g classifies some arc of L. The conclusion follows.
Now suppose that L has two or more vertices. Consider the classical graph
 $\textrm{core}(L)$
obtained by deleting the
 $\dagger$
-orbit of
 $\eth(L)$
([
Reference Hackney, Robertson and Yau33
, definition 1·9]). As
 $\textrm{core}(L)$
is connected and has more than one vertex, there exists a vertex v so that deleting v and all edges incident to it from
 $\textrm{core}(L)$
will still give a connected graph. Setting
 \begin{align*}S = nb(v)^\dagger \cap (\eth(L)\cup nb(v)),\end{align*}
we have
 $S^\dagger \subsetneq nb(v)$
; also notice that
 $S \cap S^\dagger = nb(v) \cap nb(v)^\dagger$
. Define a graph K by
 \begin{align*}V_K &= V_L \setminus \{ v\} \\[5pt] D_K &= D_L \setminus nb(v) \\[5pt] A_K &= A_L \setminus (S \cup S^\dagger).\end{align*}
We compute the boundary of K as
 \begin{align*} \eth(K) = (\eth(L) \setminus S) \cup (nb(v) \setminus S^\dagger),\end{align*}
and use this to show that
 $\eth(K)^\dagger \subseteq D_K$
. If
 $a\in \eth(L)\setminus S$
, then
 $a^\dagger \notin nb(v)$
, hence
 $a^\dagger \in D_K$
. If
 $a \in nb(v) \setminus S^\dagger$
, then we can’t have
 $a^\dagger \in \eth(L)$
for then
 $a^\dagger \in nb(v)^\dagger \cap \eth(L) \subseteq S$
, and we also can’t have
 $a^\dagger \in nb(v)$
since then
 $a \in nb(v)\cap nb(v)^\dagger \subseteq S^\dagger$
; it follows that
 $a^\dagger\in D_K$
. We have thus shown that K does not contain any edge components. As
 $\textrm{core}(K) = \textrm{core}(L) - v$
is connected, we conclude that K is connected. The inclusions of subsets give our desired embedding
 $g\colon K \rightarrowtail L$
.
Proposition 4·10.
Given an embedding
 $\ell \colon L \rightarrowtail G$
and a new graph map
 $\varphi \colon G \to G'$
, we have
 \begin{align*} \varsigma \hat \varphi [\ell] = \sum_{v\in V_L} \varsigma \hat \varphi [\ell \iota_v].\end{align*}
Proof. If L is an edge, so is
 $\hat \varphi[\ell]$
by Definition 4·2(i), hence
 $\varsigma \hat \varphi[\ell] = 0$
as desired. If L is a star, then the formula is immediate. We have thus established the formula whenever L does not contain an internal edge.
For the general result, we induct on the number of vertices of L, which we assume to have an internal edge (in other words, we are investigating what happens when L is not an edge and not a star). Applying Lemma 4·9, we obtain a diagram

with
 $\ell$
a union of h and k, and h, k vertex disjoint. Applying
 $\hat \varphi$
, we obtain embeddings

with
 $\hat \ell$
a union of
 $\hat h$
and
 $\hat k$
(by Definition 4·2(ii)) and
 $\hat h, \hat k$
vertex disjoint (by Definition 4·2(iii)), hence
 \begin{align*} \varsigma \hat \varphi [\ell] = \varsigma [\hat \ell] = \varsigma [\hat k] + \varsigma [\hat h] = \varsigma \hat \varphi [k] + \varsigma \hat \varphi [\ell \iota_v] \end{align*}
by Lemma 4·8. As K has one less vertex than L, by the induction hypothesis we have the first equality below:
 \begin{align*} \varsigma \hat \varphi [k] = \sum_{w\in V_K} \varsigma \hat \varphi [k \iota_w] = \sum_{w\in V_K} \varsigma \hat \varphi [\ell g \iota_w] = \sum_{u\in V_L \setminus \{ v\} } \varsigma \hat \varphi [\ell \iota_u].\end{align*}
The result follows by combining the previous two displays.
Proof of Theorem
4·7. Suppose
 $(\varphi_0, \hat \varphi) \colon G \to G'$
is a new graph map. We verify each of the three conditions from Definition 2·9.
-
(i) Applying Proposition 4·10 to the identity embedding
$id_G \colon G \rightarrowtail G$
, we find
\begin{align*} \sum_{v\in V_G} \varsigma(\varphi_1(v)) = \sum_{v\in V_G} \varsigma \hat \varphi[\iota_v] = \varsigma \hat \varphi[id_G] \leq \varsigma [id_{G^{\prime}}] = \sum_{w\in V_{G^{\prime}}} w. \end{align*}
-
(ii) This is the special case of the interpretation of Definition 4·2(iv) from Remark 4·3 where we take
$h = \iota_v$
: -
(iii) Suppose the boundary of G is empty, and consider an embedding
$h \colon H \rightarrowtail G'$
which represents
$\hat \varphi [id_G]$
. By Definition 4·2(iv) we have that
$\eth(H)$
is empty, hence h is an isomorphism by Lemma 2·16. By Proposition 4·10 we have Since
\begin{align*} \sum_{v\in V_G} \varsigma \varphi_1(v) = \varsigma \hat \varphi [id_G] = \varsigma [h] = \varsigma [id_{G^{\prime}}] = \sum_{w\in V_{G^{\prime}}} w.\end{align*}
$\eth(G')$
is empty, G
′ contains at least one vertex, implying that there is at least one
$v\in V_G$
with
$\varsigma \varphi_1(v) \neq 0$
.


4·2. From graphical maps to new graph maps
Recall Construction 4·5 which takes a graphical map
 $\varphi = (\varphi_0, \varphi_1) \colon G \to G'$
to the pair
 $\mathfrak{N} \varphi = (\varphi_0, \hat \varphi)$
. This function
 $\hat \varphi$
is defined so that
 $\hat \varphi [f] = [g]$
where g sits inside an active-inert factorisation of
 $\varphi f$
:

We will show that
 $\mathfrak{N} \varphi$
is a new graph map in Theorem 4·14, but first we first establish functoriality of the construction. After establishing that
 $\mathfrak{N} \varphi$
is a new graph map, we will show in Theorem 4·15 that
 $\mathfrak{N}$
and
 $\mathfrak{O}$
are inverses.
Lemma 4·11. Given a composable pair of graphical maps
 \begin{align*} G \xrightarrow{\;\;\;\;\varphi\;\;\;\;} H \xrightarrow{\;\;\;\;\psi\;\;\;\;} K\end{align*}
we have that
 $\hat \psi \circ \hat \varphi = \widehat{\psi \circ \varphi}$
. Further,
 $\widehat {id_G} = id_{\operatorname{Emb}\!(G)}$
.
Proof. The second statement is clear since we have an active-inert orthogonal factorisation system on
 $\textbf{U}$
. The first statement also follows from the factorisation system: suppose
 $\ell \colon L \rightarrowtail G$
is an embedding.

First factor
 $\varphi \ell$
as
 $f\circ p$
, and then factor
 $\psi f$
as
 $h\circ q$
, and notice that
 $h \circ (qp)$
is an active-inert factorisation of
 $\psi \varphi \ell$
. It follows that
 $\hat \varphi [\ell] = [f]$
,
 $\hat \psi [f] = [h]$
, and
 $\widehat {\psi \circ \varphi} [\ell] = [h]$
.
Our next goal is to show that
 $\mathfrak{N}$
from Construction 4·5 takes graphical maps to new graph maps. For this purpose, consider a graphical map
 $\varphi \colon G \to G'$
and embeddings
 $h,k,\ell$
into G with
 $[h] \leq [\ell]$
and
 $[k]\leq [\ell]$
. We form an active-inert factorisation
 $\hat \ell \circ \alpha$
of
 $\varphi\ell$
, and then active-inert factorisations of
 $\alpha f$
and
 $\alpha g$
as displayed below-right.

In particular, we have that
 $\hat \varphi [\ell] = [\hat \ell]$
is an upper bound for both
 $\hat \varphi [h]$
and
 $\hat \varphi [k]$
.
Lemma 4·12.
If
 $\ell$
is a union of h and k, then
 $\hat \varphi [\ell]$
is a union of
 $\hat \varphi [h]$
and
 $\hat \varphi [k]$
.
Proof. Suppose
 $v\in V_{L^{\prime}}$
. Our goal is to show that
 $\hat \ell (v)$
is an element of
 $\hat h(V'_{\!\!H}) \cup \hat k(V_{K^{\prime}})$
. Since
 $\alpha \colon L\to L'$
is active, by [
Reference Hackney, Robertson and Yau33
, proposition 2·3] there is a unique vertex
 $w\in V_L$
so that
 $\alpha_w \colon M_w \rightarrowtail L'$
(representing
 $\alpha_1(w)$
) has v in its image. As
 $V_H \amalg V_K \to V_L$
is surjective, there is a vertex w
′ of H or K mapping to w; without loss of generality we assume
 $w^{\prime}\in V_H$
. Considering the square

of (4·2), we get that the triangle

commutes by the descriptions of composing with embeddings from [
Reference Hackney, Robertson and Yau33
, definition 1·34]. Hence v is in the image of
 $H' \rightarrowtail L'$
, so
 $\hat \ell (v)$
is an element of
 $\hat h(V_{H^{\prime}})$
.
A similar line of argument gives the following.
Lemma 4·13.
If h and k are vertex disjoint, then so are
 $\hat h$
and
 $\hat k$
.
Proof. We prove the contrapositive. Suppose
 $\hat h(V_{H^{\prime}}) \cap \hat k(V_{K^{\prime}})$
is inhabited and let
 $\hat h(v^{\prime}) = \hat k(w^{\prime})$
be a vertex in this intersection. Since
 $\beta \colon H \to H'$
is active, by [
Reference Hackney, Robertson and Yau33
, proposition 2·3], there exists a unique vertex
 $v \in V_H$
so that
 $\beta_{v} \colon M_{v} \rightarrowtail H'$
(with
 $[\beta_v] = \beta_1(v)$
) has v
′ in its image. Likewise, there exists a unique vertex
 $w\in V_K$
so that
 $\gamma_w \colon N_w \rightarrowtail K'$
has w
′ in its image. We have
 $\alpha_1(f(v)) = [f' \circ \beta_v]$
and
 $\alpha_1(g(w)) = [g' \circ \gamma_w]$
by remark 1·45 of [
Reference Hackney, Robertson and Yau33
].

Now f
′(v
′) and g
′(w
′) are in the images of both
 $\alpha_1(f(v))$
and
 $\alpha_1(g(w))$
; since
 $\alpha$
is a graphical map, Definition 2·9 (i) gives
 $f(v) = g(w)$
. Hence
 $h(v) = \ell f(v) = \ell g(w) = k(w)$
, so h and k are not vertex disjoint.
Theorem 4·14.
If
 $\varphi = (\varphi_0, \varphi_1) \colon G \to G'$
is a graphical map, then
 $\mathfrak{N}\varphi = (\varphi_0, \hat\varphi)$
is a new graph map, where
 $\hat \varphi$
is as defined in Construction 4·5.
Proof. We verify the four conditions from Definition 4·2. Condition (i) follows from lemma 2·2 of [ Reference Hackney, Robertson and Yau33 ]. The preceding two lemmas give (ii) and (iii), respectively. The interpretation of (iv) given in Remark 4·3 is lemma 1·47 of [ Reference Hackney, Robertson and Yau33 ].
Theorem 4·15.
Suppose G and G′ are connected graphs. The assignments
 $\mathfrak{N}$
and
 $\mathfrak{O}$
are inverse bijections between new graph maps from G to G′ and graphical maps from G to G′. Moreover, these assignments identify the category of connected graphs and new graph maps with the category
 $\textbf{U}$
.
Proof. The conclusion will follow once we establish the bijection, as Lemma 4·11 implies that
 $\mathfrak{N}$
is an identity-on-objects functor from
 $\textbf{U}$
to the category of new graph maps.
It is nearly immediate that
 $\mathfrak{O}\mathfrak{N}$
is an identity on
 $\textbf{U}(G,G')$
, by the same reasoning as in the first bullet point of remark 1·45 of [
Reference Hackney, Robertson and Yau33
]. Namely, if
 $\varphi_v \colon H_v \rightarrowtail G'$
represents
 $\varphi_1(v)$
, then we have a factorisation in
 $\textbf{U}$

so
 $\mathfrak{O}\mathfrak{N}(\varphi)_1(v) = \hat \varphi([\iota_v]) = [\varphi_v] = \varphi_1(v)$
.
Now suppose that
 $\varphi = (\varphi_0, \hat \varphi) \colon G \to G'$
is a new graph map,
 $\mathfrak{O}(\varphi) = (\varphi_0, \varphi_1)$
is the associated graphical map, and
 $\mathfrak{N}\mathfrak{O}(\varphi) = (\varphi_0, \tilde \varphi)$
, where
 $\tilde \varphi$
is a function from
 $\operatorname{Emb}\!(G)$
to
 $\operatorname{Emb}\!(G')$
. Let
 $f \colon H \rightarrowtail G$
be an arbitrary embedding; we wish to show that
 $\tilde \varphi [f] = \hat \varphi [f]$
. Notice that we already have a special case: if the domain of f is a star, then
 $[f] = [\iota_v]$
for some
 $v \in V_G$
, and we know
 $\tilde \varphi [\iota_v] := \mathfrak{O}(\varphi)_1(v) := \hat \varphi [\iota_v]$
. Let us turn the general case.
Since
 $\varphi$
and
 $\mathfrak{N}\mathfrak{O}(\varphi)$
are new graph maps, by Remark 4·3, we have the commutative diagram

and we conclude that
 $\eth(\hat\varphi [f]) = \eth(\tilde\varphi [f])$
. This is nearly enough to conclude that
 $\hat\varphi [f]$
and
 $\tilde\varphi [f]$
are equal — the only thing that could go wrong is if one of them is an edge while the other is not. Applying Proposition 4·10 twice we have
 \begin{align*} \varsigma \hat \varphi [f] = \sum_{v\in V_H} \varsigma \hat \varphi [f\iota_v] = \sum_{v\in V_H} \varsigma \tilde \varphi[f\iota_v] = \varsigma \tilde \varphi [f]\end{align*}
where the middle equality comes from the previously established fact that
 $\hat \varphi [f\iota_v] = \tilde \varphi [f\iota_v]$
. Since an embedding h is an edge if and only if
 $\varsigma[h] = 0 $
, we conclude that
 $\hat \varphi [f]$
is an edge if and only if
 $\tilde \varphi [f]$
is an edge. By Lemma 2·15, we conclude that
 $\hat \varphi[f] = \tilde \varphi[f]$
. Thus
 $\varphi = \mathfrak{N}\mathfrak{O}(\varphi)$
.
Remark 4·16. We can describe the active-inert factorisation system on
 $\textbf{U}$
from Proposition 2·12 in terms of new graph maps. The active maps are precisely those maps
 so that
 $\hat \varphi([id_G]) = [id_{G^{\prime}}] \in \operatorname{Emb}\!(G')$
, that is, maps where
 $\hat \varphi$
preserves the top element. Likewise, the inert maps are those where
 $\hat \varphi$
admits a dashed arrow making the following diagram commute:

The factorisation of a map
 $\varphi \colon G \to G'$
can be obtained by taking
 $h\colon H \rightarrowtail G'$
to be an embedding with
 $\hat \varphi [id_G] = [h]$
, and explicitly defining an active map
 so that
 $\varphi = h \circ \psi$
. This requires a bit of delicacy, since the embedding h might not be injective on arcs.
5. Directed graphs and the wheeled properadic graphical category
We now turn our attention to the wheeled properadic graphical category. This category controls wheeled properads [ Reference Markl, Merkulov and Shadrin47 ] (which extend the notion of properad [ Reference Vallette57 ] to encode traces) in the sense that there is a relevant nerve theorem. Wheeled properads can be regarded as modular operads with additional directional structure, which was observed in [ Reference Raynor51 , example 1·29].
In this section we show how the wheeled properadic graphical category can be described in a similar manner to that of
 $\textbf{U}$
above. One drawback of the existing definition is that it relies on the notion of wheeled properad and maps between wheeled properads. Our new definition does not have this requirement, though of course we will need to consider wheeled properads to prove the equivalence. As one caveat: in this paper we consider only the version of the wheeled properadic graphical category from [
Reference Hackney, Robertson and Yau31
], rather than the one from [
Reference Hackney, Robertson and Yau29
]. The latter can be obtained from the former by inverting a single map. For brevity, we do not include the original definition of the wheeled properadic graphical category here, except indirectly in the proof of Theorem 5·13.
5·1. Directed graphs
The following encoding of a directed graph with loose ends was introduced as definition 1·1·1 of [ Reference Kock43 ].
Definition 5·1 (Directed graphs). Let
 $\mathscr{G}$
denote the category

A directed graph G is a functor
 $\mathscr{G} \to \textbf{FinSet}$
which sends the two maps with codomain
 $\texttt{e}$
to monomorphisms, that is, a directed graph is a diagram of finite sets of the form
 \begin{align*} E_{G} \hookleftarrow I_{G} \rightarrow V_{G} \leftarrow O_{G} \hookrightarrow E_{G}. \end{align*}
Each vertex
 $v\in V_G$
has a set of inputs
 $\operatorname{in}\!(v) \subseteq I_G$
which is the preimage of v under
 $I_G \to V_G$
, and likewise has a set of outputs
 $\operatorname{out}\!(v) \subseteq O_G$
. The set of inputs of G is defined to be
 $\operatorname{in}\!(G) := E_G \setminus O_G$
and the set of outputs of G is
 $\operatorname{out}\!(G) := E_G \setminus I_G$
.
Directed graphs in this sense turn out to be equivalent to others in the literature (this is mostly due to Batanin–Berger; see Proposition C12 and [ Reference Chu and Hackney11 , remark 2·0·2]), with the caveat that it is not possible to encode graphs with components that are nodeless loops. See Definition C7 below for a ‘hack’ that fixes this problem, which is similar to that appearing in definition 4·1 of [ Reference Hackney, Robertson and Yau33 ].
A key upside to Kock’s definition compared to other formalisms is that it is admits a straightforward notion of étale maps [ Reference Kock43 , 1·1·7] as certain natural transformations, similar to that of Definition 2·3.
Definition 5·2. An étale map
 $f\colon G \to H$
between directed graphs is a commutative diagram of sets

so that the middle two squares are pullbacks. An embedding is an étale map between connected directed graphs which is injective on vertices.
These embeddings of directed graphs correspond to those for undirected graphs in Definition 2·3. They are different from the ‘open subgraph inclusions’ of [
Reference Kock43
], since the edge map
 $f|_E$
is not required to be injective and the domain and codomain must be connected.
We now relate the definitions of directed and undirected graphs.
Definition 5·3 (Orientation presheaf). The orientation presheaf, denoted
 $\mathfrak{o}$
, is the
 $\textbf{U}$
-presheaf so that
 \begin{align*}\mathfrak{o}_G \subseteq \prod_{a\in A_G} \{ +1, -1 \}\end{align*}
consists of those elements
 $x = (x_a)$
satisfying
 $x_a = -x_{a^\dagger}$
for all
 $a\in A_G$
. If
 $\varphi \colon H \to G$
is a graphical map and
 $x\in \mathfrak{o}_G$
, then
 $\varphi^*(x) \in \mathfrak{o}_H$
is the element with
 \begin{align*} \varphi^*(x)_a = x_{\varphi_0(a)}\end{align*}
for all
 $a\in A_H$
.
Pairs (G, x) consisting of a connected undirected graph
 $G \in \textbf{U}$
and an element
 $x\in \mathfrak{o}_G$
(equivalently a map of presheaves
 $x \colon G\to \mathfrak{o}$
) coincide with the connected directed graphs of Definition 5·1. This is a special case of [
Reference Kock43
, 1·1·13], and in order to fix conventions the following construction exhibits one direction of the correspondence; the reverse direction sends a directed graph to an undirected graph with
 $D = I \amalg O$
and
 $A = E\amalg E$
. See also Proposition 5·6.
Construction 5·4. If G is a graph and
 $x\in \mathfrak{o}_G$
, then we have a splitting of
 $A_G$
as
 \begin{align*}A_G^+ &= \{ a \in A_G \mid x_a = +1\} \\[5pt] A_G^- &= \{ a \in A_G \mid x_a = -1 \}\end{align*}
and likewise for
 $D_G = D_G^+ \amalg D_G^-$
. We thus obtain a diagram of sets
 \begin{align*} A_G^- \hookleftarrow D_G^- \rightarrow V_G \leftarrow D_G^+ \hookrightarrow A_G^+. \end{align*}
There are isomorphisms
 $A_G^- \xrightarrow{\cong} E_G \xleftarrow{\cong} A_G^+$
, each sending an arc a to the edge
 $[a,a^\dagger]$
it spans, so we conclude that (G, x) determines a diagram
 \begin{align*} E_G \hookleftarrow D_G^- \rightarrow V_G \leftarrow D_G^+ \hookrightarrow E_G, \end{align*}
as in Definition 5·1.
Remark 5·5. When working with this presentation, we have, for a vertex
 $v \in V_G$
 \begin{align*} \operatorname{in}\!(v) = nb(v) \cap D_G^- &\subseteq D_G^-\\[5pt] \operatorname{out}\!(v) = nb(v) \cap D_G^+ &\subseteq D_G^+.\end{align*}
We prefer to think about
 $\operatorname{in}\!(G)$
and
 $\operatorname{out}\!(G)$
as subsets of
 $A_G^+$
and
 $A_G^-$
, rather than as subsets of
 $E_G$
:
 \begin{align*} \operatorname{in}\!(G) = \eth(G) \cap A_G^+ &\subseteq A_G^+\\[5pt] \operatorname{out}\!(G) = \eth(G) \cap A_G^- &\subseteq A_G^-.\end{align*}
Notice the discrepancy in signs. This is because arcs in nb(v) point towards the vertex while arcs in
 $\eth(G)$
point away from the graph. We think about input edges as coming in from above and output edges as coming in from below, so arcs of
 $\operatorname{in}\!(v)$
point down while arcs of
 $\operatorname{in}\!(G)$
point up.
Every étale map of directed graphs induces an étale map of the corresponding undirected graphs (this was also mentioned in [ Reference Kock43 , 1·1·13]). This restricts to embeddings, yielding the following equivalence.
Proposition 5·6.
There is an equivalence of categories between the category of connected directed graphs and embeddings (in the sense of Definitions 5·1 and 5·2) and the category
 $\textbf{U}_{\textrm{int}} \times_{\widehat{\textbf{U}}} \widehat{\textbf{U}}_{/\mathfrak{o}} =: \textbf{U}^{\textrm{int}}_{/\mathfrak{o}}$
.
This proposition can’t be promoted as is to the category of graphs and étale maps, since étale maps between connected graphs which are not embeddings do not yield maps in
 $\textbf{U}$
.
Definition 5·7 (Inputs and outputs of embeddings). Suppose G is a directed graph. Then there are functions
 $\operatorname{in} \colon \operatorname{Emb}\!(G) \to \wp(A_G^+) \cong \wp(E_G)$
and
 $\operatorname{out} \colon \operatorname{Emb}\!(G) \to \wp(A_G^-) \cong \wp(E_G)$
defined by
 \begin{align*} \operatorname{in}\!([f]) &= \eth([f]) \cap A_G^+ \\[5pt] \operatorname{out}\!([f]) &= \eth([f]) \cap A_G^-. \end{align*}
Alternatively, we can consider
 $f\colon (H,f^*x) \rightarrowtail (G,x)$
as an embedding between directed graphs and we have
 \begin{align*}\operatorname{in}\!(f) &= f(\!\operatorname{in}\!(H)) \subseteq A_G^+ \\ \operatorname{out}\!(f) &= f(\!\operatorname{out}\!(H)) \subseteq A_G^-.\end{align*}
5·2. Wheeled properads and the oriented graphical category
We now introduce the oriented graphical category
 $\textbf{U}_{/\mathfrak{o}}$
, which we will show is equivalent to the wheeled properadic graphical category. Thus, by the nerve theorem (theorem 10·33 and proposition 10·35 of [
Reference Hackney, Robertson and Yau29
]), this category governs wheeled properads. More precisely, the category of (set-based) wheeled properads is equivalent to the category of Segal presheaves on
 $\textbf{U}_{/\mathfrak{o}}$
(in the sense of Definition 6·13).
Definition 5·8 (Oriented graphical category). The oriented graphical category is the category
 $\textbf{U}_{/\mathfrak{o}} := \textbf{U} \times_{\widehat{\textbf{U}}} \widehat{\textbf{U}}_{/\mathfrak{o}}$
whose objects are pairs consisting of an undirected graph G and map of presheaves
 $x \colon G \to \mathfrak{o}$
(equivalently an element
 $x \in \mathfrak{o}_G$
).
Remark 5·9. By Definition 5·3, if G is a graph, then an element
 $x\in \mathfrak{o}_G$
is the same thing as an involutive map from
 $A_G$
to
 $\{ +1, -1 \}$
. A map
 $(G,x) \to (G',x')$
in
 $\textbf{U}_{/\mathfrak{o}}$
is a just a map
 $G\to G'$
in
 $\textbf{U}$
so that the triangle

commutes.
The following uses the two functions appearing in Definition 5·7 and the correspondence from Construction 5·4 to reinterpret Definition 4·2 in the oriented setting.
Proposition 5·10.
A map
 $\varphi \colon (G,x) \to (G',x')$
in the oriented graphical category
 $\textbf{U}_{/\mathfrak{o}}$
may be described as a pair
 $(\bar\varphi_0, \hat\varphi)$
consisting of functions
 $\bar\varphi_0 \colon E_G \to E'_{\!\!G}$
and
 $\hat \varphi \colon \operatorname{Emb}\!(G) \to \operatorname{Emb}\!(G')$
so that (i), (ii) and (iii) from Definition 4·2 hold and, additionally,
-
(iv’) the diagram
commutes.

Definition 5·11. The Moerdijk–Weiss dendroidal category, denoted
 $\boldsymbol{\Omega}$
, is the full subcategory of
 $\textbf{U}_{/\mathfrak{o}}$
consisting of those graphs G so that
 $\operatorname{out}\!(v)$
is a singleton set for every
 $v\in V_G$
. Alternatively, it consists of those graphs G so that
 $\operatorname{out} \colon \operatorname{Emb}\!(G) \to \mathbb{N}E_G$
factors through
 $E_G \hookrightarrow \mathbb{N}E_G$
.
Remark 5·12. The equivalence of the usual definition of
 $\boldsymbol{\Omega}$
from [
Reference Moerdijk and Weiss48
, section 3] with Definition 5·11 follows, for instance, from Corollary B21 and [
Reference Hackney, Robertson and Yau29
, remark 6·55]. But this may also be seen more directly by comparing Proposition 5·10 with the presentation of the dendroidal category as the dendroidally ordered broad posets from [
Reference Weiss60
, section 2·1·4]. Indeed, it turns out that for each
 $G\in \boldsymbol{\Omega}$
, we have
 $\operatorname{out} \times \operatorname{in} \colon \operatorname{Emb}\!(G) \hookrightarrow E_G \times \mathbb{N}E_G$
is an inclusion, giving a heterogeneous relation between
 $E_G$
and
 $\mathbb{N}E_G$
. This relation is the relevant broad poset structure on
 $E_G$
, and condition (iv') is merely asserting that
 $\bar\varphi_0 \colon E_G\to E'_{\!\!G}$
is a map of broad posets.
Our aim in this subsection is to prove the following theorem.
Theorem 5·13.
The oriented graphical category
 $\textbf{U}_{/\mathfrak{o}}$
is equivalent to the wheeled properadic graphical category which excludes the nodeless loop.
This version of the wheeled properadic graphical category was called
 $\mathcal{B}$
in [
Reference Hackney, Robertson and Yau31
, section 2]. The nodeless loop in question shows up as Example C9, but does not appear among the graphs defined in Definition 5·1. An extension of the preceding theorem will be given in Theorem C14.
Remark 5·14 (A change to objects). The objects of the wheeled properadic category from [
Reference Hackney, Robertson and Yau29, Reference Hackney, Robertson and Yau31
] are (isomorphism classes of) graphs equipped with a listing, that is, a total ordering on each of the subsets
 $\operatorname{in}\!(v)$
,
 $\operatorname{out}\!(v)$
(both as v varies),
 $\operatorname{in}\!(G)$
, and
 $\operatorname{out}\!(G)$
of
 $E_G$
. Every graph admits such a listing, and if we consider two choices of listing for the same graph, then there is a canonical isomorphism between them in the wheeled properadic graphical category. In what follows, we consider only the equivalent category whose objects coincide with the objects of
 $\textbf{U}_{/\mathfrak{o}}$
(resp., with the objects of
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
in Appendix C·1). That is, we are considering all directed graphs rather than just isomorphism classes of such, and we are not imposing a listing. The equivalence can be realised by choosing, for each directed graph
 $G \in \textbf{U}_{/\mathfrak{o}}$
, some fixed listing and then passing to the associated isomorphism class. The term ‘wheeled properadic graphical category’ will refer to this equivalent category henceforth.
We will need a few preliminary results before tackling the proof of Theorem 5·13. The main one is the following, which is the directed analogue of the construction from section 2·2 of [ Reference Hackney, Robertson and Yau34 ]. As this is just a minor variation of the undirected case, we merely provide a sketch and refer the reader to [ Reference Hackney, Robertson and Yau34 ] for details.
Proposition 5·15.
There is a functor
 $F \colon \textbf{U}_{/\mathfrak{o}} \to \textbf{WPpd}$
from the oriented graphical category to the category of (colored) wheeled properads [
Reference Hackney, Robertson and Yau29
, definition 9·1] which takes a directed graph to the wheeled properad it freely generates.
Proof sketch. On objects the value of F is given in the same was as in [
Reference Hackney, Robertson and Yau29
, section 9·2·1]. Briefly, if G is a directed graph then F(G) is the free
 $E_G$
-colored wheeled properad which has one generator for each vertex
 $v\in V_G$
. For each vertex v, choose orderings
 $\operatorname{in}\!(v) = e_1, \dots, e_m$
and
 $\operatorname{out}\!(v) = e'_{\!\!1}, \dots, e'_{\!\!n}$
for the inputs and output edges of v, and regard v as a generator in the set
 \begin{equation} v\in F(G)(e_1, \dots, e_m;\; e'_{\!\!1}, \dots, e'_{\!\!n}).\end{equation}
If H is a graph equipped with a total ordering of the sets
 $\operatorname{in}\!(H) = \{i_1, \dots, i_k\}$
and
 $\operatorname{out}\!(H) = \{o_1, \dots, o_j\}$
, then an étale map
 $\mu \colon H \to G$
determines an element in
 \begin{align*} F(G)(\mu i_1, \dots, \mu i_k;\; \mu o_1, \dots, \mu o_j).\end{align*}
Given a graphical map
 $\varphi \colon G \to G'$
, using that F(G) is a free wheeled properad we can specify a map of wheeled properads (see [
Reference Hackney, Robertson and Yau29
, lemma 9·23])
 \begin{align*} F\varphi = f \colon F(G) \longrightarrow F(G')\end{align*}
by defining the color map
 $E_G \to E_{G^{\prime}}$
to be
 $\bar \varphi_0$
, and value on the generator (5·1),
 \begin{align*} f_1(v) \in F(G)(fe_1, \dots, fe_m;\;\, fe'_{\!\!1}, \dots, fe'_{\!\!n}),\end{align*}
is given by the embedding
 $\varphi_1(v)$
. Composition is defined using graph substitution, and associativity of composition is proved as in [
Reference Hackney, Robertson and Yau34
, proposition 2·25].
In Lemma 5·20 we will compare embeddings with the notion of ‘subgraph’ from Definition 9·50 of [ Reference Hackney, Robertson and Yau29 ], and to do so it will be convenient to have the following notion of ‘graph complement’ at hand. We show that such graph complements always exist in Lemma 5·19 (for completeness, we also prove they are unique in Lemma 5·18). See Figure 7 for a pair of examples.
Two examples of graph complement.

Definition 5·16. Let
 $f \colon G \rightarrowtail H$
be an embedding of (undirected or directed) connected graphs (in
 $\textbf{U}_{\textrm{int}}$
or
 $\textbf{U}^{\textrm{int}}_{/\mathfrak{o}}$
). A graph complement of f consists of a triple
 $(K,v^G,\alpha)$
where K is another connected graph,
 $v^G \in V_K$
is a distinguished vertex, and
 is an active map. This data must satisfy
 $\alpha_1(v^G) = [f]$
and, for all other vertices
 $v \in V_K\setminus \{v^G\}$
, there is a vertex
 $w\in V_H$
with
 $\alpha_1(v) = [\iota_w]$
.
It is implicit that if f is an embedding of directed graphs, then K should be directed and
 $\alpha$
should be an active map in
 $\textbf{U}_{/\mathfrak{o}}$
. In either case, since
 $\alpha$
is active, every vertex w of H is either in
 $f(V_G)$
or comes from a unique
 $v\in V_K \setminus \{v^G\}$
where
 $\alpha_1(v) = [\iota_w]$
. Thus
 $\alpha$
induces a bijection
 $V_K \setminus \{v^G\} \cong V_H \setminus f(V_G)$
.
Remark 5·17 (Relation to étale complement). By deleting the vertex
 $v^G$
from K (retaining all of the arcs, but removing
 $nb(v^G)$
from
 $D_K$
), we obtain another graph K′ which comes equipped with an étale map
 $K' \to H$
. The graph K′ will frequently be disconnected. If the embedding
 $f \colon G \rightarrowtail H$
is injective on arcs, then we could ask what the relationship is between K
′ and the étale complement of f from [
Reference Kock43
, 1·6·2--1·6·4]. These turn out to coincide if either G contains at least one vertex or if f classifies an internal edge of H. If f classifies an incoming or outgoing edge of H, then
 $K' \cong {{\updownarrow}} \amalg H$
, whereas the étale complement is H.
The following lemma is not strictly necessary for the developments below, but is included for completeness.
Lemma 5·18. Graph complements are unique up to isomorphism.
Proof. Suppose
 $(K, v^G, \alpha)$
and
 $(J, u^G, \beta)$
are two graph complements of an embedding
 $f \colon G \rightarrowtail H$
. The isomorphisms
 \begin{align*} V_K \setminus \{v^G \} \xrightarrow{\cong} V_H \setminus f(V_G) \xleftarrow{\cong} V_J \setminus \{u^G \}\end{align*}
extend to a bijection
 $z_V \colon V_K \to V_J$
sending
 $v^G$
to
 $u^G$
.
By Definition 2·9(ii) we have

and these isomorphisms
 $nb(v) \to nb(z_V(v))$
assemble into a bijection
 \begin{align*} z_D \colon D_K = \coprod_{v\in V_K} nb(v) \to \coprod_{u \in V_J} nb(u) = D_J\end{align*}
over
 $z_V \colon V_K \cong V_J$
. Finally, since
 $\alpha$
and
 $\beta$
are active we have isomorphisms

which gives
 \begin{align*} z_A \colon A_K = D_K \amalg \eth(K) \xrightarrow{\cong} D_J \amalg \eth(J) = A_J.\end{align*}
If
 $a \in nb(v)$
(resp.
 $a \in \eth(K)$
) then
 $z_A(a) = z_D(a) \in nb(z_V(v))$
(resp.
 $z_A(a) \in \eth(J)$
) is the unique element satisfying
 $\alpha_0(a) = \beta_0(z_A(a))$
.
The only thing to check is that
 $z_A\colon A_K \to A_J$
preserves the involution.
If G is not an edge, then
 $\alpha_0$
and
 $\beta_0$
are injective by lemma 2·9 of [
Reference Hackney, Robertson and Yau33
], so
 $z_A(a)$
is defined by the equation
 $\alpha_0(a) = \beta_0(z_A(a))$
with no stipulation about where a or
 $z_A(a)$
live. Using this equation for both a and
 $a^\dagger$
, we have
 \begin{align*} \beta_0(z_A(a^\dagger)) = \alpha_0(a^\dagger) = \alpha_0(a)^\dagger = \beta_0(z_A(a))^\dagger = \beta_0(z_A(a)^\dagger),\end{align*}
hence
 $z_A(a^\dagger) = z_A(a)^\dagger$
.
If G is an edge, then again using lemma 2·9 of [
Reference Hackney, Robertson and Yau33
] we have
 $\alpha_0$
is injective when restricted to
 $A_K \setminus nb(v^G)$
. Writing
 $nb(v^G) = \{d_0,d_1\}$
, the only identifications that
 $\alpha_0$
makes are
 $\alpha_0(d_0) = \alpha_0(d_1^\dagger)$
and
 $\alpha_0(d_1) = \alpha_0(d_0^\dagger)$
. A similar situation occurs with
 $\beta_0$
and
 $nb(u^G)$
. Thus, as in the previous paragraph,
 $z_A(a^\dagger) = z_A(a)^\dagger$
so long as
 $a\notin \{d_0,d_1,d_0^\dagger,d_1^\dagger\}$
. But now
 $nb(u^G) = \{ z_A(d_0), z_A(d_1) \}$
, and the only way for our bijection to not be involutive would be if
 $z_A(d_0^\dagger) = z_A(d_1)^\dagger$
and
 $z_A(d_1^\dagger) = z_A(d_0)^\dagger$
. This cannot happen, as
 \begin{align*} \beta_0 (z_A(d_0^\dagger)) = \alpha_0(d_0^\dagger) = \alpha_0(d_1)\neq \alpha_0(d_1)^\dagger= \beta_0(z_A(d_1))^\dagger.\end{align*}
Lemma 5·19.
If
 $f \colon G \rightarrowtail H$
is an embedding between connected (directed or undirected) graphs, then a graph complement of f exists.
This lemma is closely related to the notion of a ‘shrinkable pasting scheme,’ which includes the pasting scheme for connected directed graphs by proposition 3·3(i) of [ Reference Hackney, Robertson and Yau30 ]. One can iteratively shrink away (in the graph H) all edges coming from internal edges of G and identify their end vertices, and this will yield the graph complement (so long as G is not an edge). See the discussion following remark 3·8 of [ Reference Hackney, Robertson and Yau30 ] for more on this viewpoint; in the following proof we simply give formulas for the resulting graph K.
Proof. We can ignore directionality when constructing the graph complement: if the embedding f is a map in
 $\textbf{U}_{/\mathfrak{o}}$
, then the produced undirected graph K becomes directed via the composite map of presheaves
 $K \to H \to \mathfrak{o}$
.
We first address the special case when G does not have a vertex. If G is an edge hitting arcs
 $a_0, a_1 \in A_H$
(with
 $a_0^\dagger = a_1$
), we set
 $V_K = V_H \amalg \{ v^G \}$
,
 $nb(v^G)$
consists of two new elements
 $d_0$
and
 $d_1$
,
 $D_K = D_H \amalg nb(v^G)$
,
 $A_K = A_H \amalg \{d_0,d_1\}$
, and all structure the same except that
 $a_i^\dagger$
is redefined to be
 $d_i$
for
 $i=0,1$
. The definition of
 $\alpha \colon K \to H$
is forced by the requirements in Definition 5·16.
Now suppose that G has at least one vertex. Define the following three sets
 \begin{align*}V_K &= (V_H \setminus f(V_G)) \amalg \{v^G\} \cong V_H / {\sim} \\[5pt] D_K &= D_H \setminus \{ f(d) \mid d, d^\dagger \in D_G \} \\[5pt] A_K &= A_H \setminus \{ f(d) \mid d, d^\dagger \in D_G \}.\end{align*}
The quotient presentation for
 $V_K$
identifies all of the vertices of
 $f(V_G) \subseteq V_H$
to a single vertex
 $v^G$
. We thus have a map
 $D_K \hookrightarrow D_H \to V_H \to V_H/{\sim} \cong V_K$
. The set
 $A_K$
inherits an involutive structure from
 $A_H$
. This data defines a graph K. Notice that
 $\eth(K) = A_K \setminus D_K = A_H \setminus D_H = \eth(H)$
.
There is a clear candidate for a graphical map
 $\alpha \colon K \to H$
which is an inclusion on arcs and satisfies
 $\varphi_1(v) = [\iota_v]$
for
 $v\in V_H \setminus f(V_G)$
and
 $\varphi_1(v) = [f]$
for
 $v=v^G$
. This satisfies the conditions from Definition 2·9; the only thing to note is that
 $nb(v^G) = f(\eth(G)^\dagger)$
which is used in showing (ii). The triple
 $(K,v^G,\alpha)$
satisfies the conditions of Definition 5·16.
Lemma 5·20.
The functor
 $F \colon \textbf{U}_{/\mathfrak{o}} \to \textbf{WPpd}$
gives a bijection between embeddings
 $G \rightarrowtail G'$
in
 $\textbf{U}^{\textrm{int}}_{/\mathfrak{o}}$
and subgraphs
 $F(G) \to F(G')$
in the sense of [
Reference Hackney, Robertson and Yau29
, definition 9·50].
Proof. Suppose
 $f \colon G \rightarrowtail G'$
is an embedding, which determines a map of wheeled properads
 $F(f) \colon F(G)\to F(G')$
by Proposition 5·15. Let
 be the graph complement of f from Lemma 5·19. Since
 $\alpha$
is active, it induces an isomorphism
 $K\{G\} \cong G'$
by definition 1·39 and proposition 2·3 of [
Reference Hackney, Robertson and Yau33
]; here
 $K\{G\}$
is the graph substitution of G into the vertex
 $v^G$
of K (see construction 1·18 of [
Reference Hackney, Robertson and Yau33
]). By theorem 9·52 of [
Reference Hackney, Robertson and Yau29
],
 $F(G) \to F(G')$
is a subgraph.
Now suppose that
 $f \colon F(G) \to F(G')$
is a map of wheeled properads which is a subgraph. By theorem 9·52 of [
Reference Hackney, Robertson and Yau29
] there is a graph substitution decomposition
 $K\{G\} \cong G'$
so that f sends the edges and vertices in G to their corresponding images in
 $K\{G\}$
through this isomorphism. As we always have an embedding
 $G \rightarrowtail K\{G\}$
, we see that the composition
 $G \rightarrowtail K\{G\} \cong G'$
is an embedding in
 $\textbf{U}_{/\mathfrak{o}}$
. The two indicated constructions are inverses to one another.
Proof of Theorem
5·13. Recall from Remark 5·14 that we are taking the objects of the wheeled properadic graphical category, denoted in this proof by
 $\textbf{C}$
, to be the same as the objects of
 $\textbf{U}_{/\mathfrak{o}}$
. This category comes with a faithful (but non-full) functor
 $\textbf{C} \to \textbf{WPpd}$
which has the same action on objects as the functor
 $F \colon \textbf{U}_{/\mathfrak{o}} \to \textbf{WPpd}$
from Proposition 5·15. Our strategy is to exhibit a lift

which is the identity-on-objects, makes the triangle commute, and is fully-faithful.
Suppose G and G
′ are objects in
 $\textbf{U}_{/\mathfrak{o}}$
, and let
 $f \colon F(G) \to F(G')$
be a map of wheeled properads. The image ([
Reference Hackney, Robertson and Yau29
, definition 9·55]) of f is the G
′-decorated graph
 $(f_0G)\{f_1(u)\}$
. Namely,
 $f_1(u)$
is given by a connected graph
 $K_u$
together with an étale map
 $K_u \to G'$
, and
 $(f_0G)\{f_1(u)\}$
is the (connected) graph substitution
 $G\{K_u\}_{u\in V_G}$
together with the induced étale map. An embedding
 $h\colon H \rightarrowtail G$
determines a subgraph
 $F(H) \to F(G)$
by the equivalence of Lemma 5·20, and there is an associated image of this subgraph given as the étale map
 \begin{equation} H\{K_{hv}\}_{v\in V_H} \longrightarrow G\{K_{u}\}_{u\in V_G} \longrightarrow G'. \end{equation}
Leaning on the equivalence from Lemma 5·20, by [
Reference Hackney, Robertson and Yau29
, theorem 9·62] the map f constitutes a morphism in
 $\textbf{C}(G,G')$
if and only if for every embedding h the étale map (5·3) is an embedding. When
 $f= F\varphi$
, by Construction 4·5 we have that (5·3) is an embedding representing
 $\hat \varphi [h]$
, hence
 $F\varphi$
is in
 $\textbf{C}(G,G')$
. On the other hand, if
 $f\in \textbf{C}(G,G')$
is an map in the wheeled properadic graphical category, we can define a graphical map
 $\varphi \colon G \to G'$
by setting
 $\bar \varphi_0 = f_0 \colon E_G \to E_G$
and letting
 $\hat \varphi [h]$
be the embedding (5·3) (or using the special case when
 $h = \iota_v$
and letting
 $\varphi_1(v)$
be represented by the embedding
 $K_v \rightarrowtail G'$
associated to
 $f_1(v)$
). Using properties of graph substitution, one checks that
 $(\bar \varphi_0, \hat \varphi)$
satisfies the conditions from Proposition 5·10, hence constitutes a morphism in
 $\textbf{U}_{/\mathfrak{o}}(G,G')$
.
By looking at their actions on edges and vertices, we see that the two assignments
 $\varphi \mapsto F\varphi$
and
 $f \mapsto \varphi$
are inverses. Thus the desired identity-on-objects lift (5·2) of F exists and is fully-faithful.
Remark 5·21. An observant reader may have noticed that we glossed over a subtlety in the second paragraph of the preceding proof, namely the fact that our current formalism for graphs does not include nodeless loops (Example C9). It is possible that either
 $K_u$
or one of the graph substitutions
 $G\{K_u\}$
,
 $H\{K_{hv}\}$
is a nodeless loop, in which case one should be careful with the phrase étale map (here it should mean a natural transformation satisfying Definition C10(1) from Appendix C). This is not so important, but what is important is that we never regard the map (5·3) as an embedding when
 $H\{K_{hv}\}$
is a nodeless loop. This follows from [
Reference Hackney, Robertson and Yau29
, theorem 9·52] since G
′ is not a nodeless loop, and also matches our later convention from Definition C10.
6. Hypermoment categories, algebraic patterns, Segal presheaves
We now turn to the structure of graph categories that make them suitable for describing various kinds of operadic structures (operads, properads, cyclic operads, and so on). This is all akin to how the inclusion of the simplicial indexing category
 $\boldsymbol{\Delta} \hookrightarrow \textbf{Cat}$
induces a fully-faithful functor
 $\textbf{Cat} \to \widehat{\boldsymbol{\Delta}}$
, and we can identify its essential image as those simplicial sets X satisfying a Segal condition
 \begin{align*} X_n \cong X_1 \times_{X_0} X_1 \times_{X_0} \cdots \times_{X_0} X_1\end{align*}
(see Definition 6·13). We will situate our discussion within the (closely related) general frameworks of Berger’s hypermoment categories [ Reference Berger9 ] and the algebraic patterns of Chu–Haugseng [ Reference Chu and Haugseng13 ].
In this section, we will discuss all of the graph categories that appear in Figure 2 of the introduction, though several such only make their appearances in appendices:
-
(i) the full subcategories
$\textbf{U}_{\textrm{cyc}} \subset \textbf{U}_{0} \subset \textbf{U}$
consist of those undirected graphs which are simply-connected, and graphs in
$\textbf{U}_{\textrm{cyc}}$
have non-empty boundary. These categories are considered in Appendix A; -
(ii) the properadic graphical category
$\textbf{G}$
from Definition B9 (called
$\boldsymbol{\Gamma}$
in [
Reference Hackney, Robertson and Yau29
]), which is a non-full subcategory of
$\textbf{U}_{/\mathfrak{o}}$
(see Theorem B18) whose objects are acyclic directed graphs; -
(iii) the dioperadic graphical category
$\textbf{G}_{\textrm{sc}}$
(called
$\boldsymbol{\Theta}$
in [
Reference Hackney, Robertson and Yau29
]), which is a full subcategory of both
$\textbf{G}$
and
$\textbf{U}_{/\mathfrak{o}}$
on the simply-connected graphs; -
(iv) the extended graphical category
$\widetilde{\textbf{U}}$
and the extended oriented graphical category
$\widetilde{\textbf{U}}_{/\mathfrak{o}}$
, which appear in Appendix C. These include a single new object (up to isomorphism), the nodeless loop, which does not fit into our earlier graphs definition.


The appendices that the categories from the first three bullet points appear in are mainly devoted to comparing alternative descriptions of these categories, and these descriptions are not necessary for understanding this section. In particular, the first and third bullet points give everything that’s needed to think about
 $\textbf{U}_{\textrm{cyc}}$
,
 $\textbf{U}_{0}$
, and
 $\textbf{G}_{\textrm{sc}}$
, while one can take Definition B4 and Theorem B18 as providing a definition of
 $\textbf{G}$
. A reader wanting a shortcut for the extended graphical categories can rely on Proposition C3 and the statement of Theorem C6 for
 $\widetilde{\textbf{U}}$
, and Definition C13 for
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
. Alternatively, the reader may elect to ignore all of these additional categories and focus on the particular cases of
 $\textbf{U}$
and
 $\textbf{U}_{/\mathfrak{o}}$
.
Remark 6·1 (Factorisation system on pointed finite sets). Recall that the category of finite pointed sets,
 $\textbf{FinSet}_*$
, has an inert-active factorisation system (see remark 2·1·2·2 of [
Reference Lurie44
]). A basepoint-preserving function
 $f \colon X \to Y$
is inert if
 $f^{-1}(y)$
has cardinality 1 whenever y is not the basepoint, and is active if the preimage of the basepoint of Y is just the basepoint of X.
If A is a finite set and
 $A_+$
is A together with an added basepoint, then maps
 $A_+ \to B_+$
correspond to partial functions
 $A \rightsquigarrow B$
. Under this interpretation, active maps correspond to total functions
 $A\to B$
. Inert maps are those which give a bijection when restricted to their domain of definition. (In this interpretation, a partial map
 $A \rightsquigarrow B$
factors as
 $A \rightsquigarrow W \to B$
, where
 $W\subseteq A$
is the domain of definition.)
It follows that
 $\textbf{FinSet}_{\ast}^{\textrm{op}}$
has an active-inert factorisation system; we also utilize a skeleton
 $\textbf{F}_{\ast}^{\textrm{op}} \subseteq \textbf{FinSet}_{\ast}^{\textrm{op}}$
with objects
 $\langle{n}\rangle = \{1, \dots, n\}\amalg \{ \ast \}$
for
 $n\geq 0$
. The category
 $\textbf{F}_{\ast}^{\textrm{op}}$
is isomorphic to Segal’s category
 $\Gamma$
[
Reference Segal54
]. Inert maps
 $\langle{1}\rangle \rightarrowtail X$
in
 $\textbf{FinSet}_{\ast}^{\textrm{op}}$
classify non-basepoint elements of X.
Definition 6·2. Let
 $\textbf{C}$
be a category equipped with an active-inert factorisation system and a functor
 $\gamma \colon \textbf{C} \to \textbf{FinSet}_{\ast}^{\textrm{op}}$
which respects the factorisation systems.
-
(i) An object
$u \in \textbf{C}$
is a unit just when-
−
$\gamma(u) \cong \langle{1}\rangle$
, and -
− any active map with codomain u has precisely one inert section.
-


-
(ii) A nilobject is an object
$c\in \textbf{C}$
with
$\gamma(c) \cong \langle{0}\rangle$
.


The following is from [ Reference Berger9 , definition 3·1], and would be called a unital hypermoment category there.
Definition 6·3. A hypermoment category consists of a category
 $\textbf{C}$
, an active-inert factorisation system on
 $\textbf{C}$
, and a functor
 $\textbf{C} \to \textbf{F}_{\ast}^{\textrm{op}}$
respecting the factorisation systems. These data must satisfy the following:
-
(1) for each
$c \in \textbf{C}$
and each inert map
$\langle{1}\rangle \rightarrowtail \gamma(c)$
in
$\textbf{F}_{\ast}^{\textrm{op}}$
, there is an essentially unique inert lift
$u \rightarrowtail c$
where u is a unit; -
(2) for each
$c\in \textbf{C}$
, there is an essentially unique active map
whose domain is a unit.


Remark 6·4. One may replace the skeleton
 $\textbf{F}_{\ast}^{\textrm{op}}$
in the preceding definition with the larger category
 $\textbf{FinSet}_{\ast}^{\textrm{op}}$
by weakening what is meant by ‘lift’ in (1), i.e. by requiring composition with the unique isomorphism
 $\langle{1}\rangle \cong \gamma(u) \rightarrowtail \gamma(c)$
yields the original map
 $\langle{1}\rangle \rightarrowtail \gamma(c)$
. We will generally use this more expansive version without comment, and only provide functors
 $\gamma \colon \textbf{C} \to \textbf{FinSet}_{\ast}^{\textrm{op}}$
. This is fine, as the inclusion from
 $\textbf{F}_{\ast}^{\textrm{op}}$
to
 $\textbf{FinSet}_{\ast}^{\textrm{op}}$
is an equivalence.
Examples of hypermoment categories include the dendroidal category
 $\boldsymbol{\Omega}$
from Definition 5·11 and the properadic graphical category
 $\textbf{G}$
from Definition B9, each equipped with the functor
 $G \mapsto (V_G)_+$
(see [
Reference Berger9
, 3·4], [
Reference Chu and Hackney11
, 2·2·22--23]).
Example 6·5. The graphical category
 $\textbf{U}$
(or the extended version
 $\widetilde{\textbf{U}}$
) is a hypermoment category. We define a functor
 $\gamma \colon \textbf{U} \to \textbf{FinSet}_{\ast}^{\textrm{op}}$
which on objects sends G to
 $(V_G)_+$
. There is a composite function (see Definition 2·8)

and the desired map of finite pointed sets
 \begin{align*} \gamma(\varphi)^{\textrm{op}} \colon (V_{G^{\prime}})_+ \longrightarrow (V_G)_+\end{align*}
sends all elements of
 $t_{\varphi}(v) \subseteq V_{G^{\prime}}$
to
 $v\in V_G$
, and all elements in
 $V_{G^{\prime}} \setminus \bigcup_v t_{\varphi}(v)$
to the basepoint. This map is singly-defined by Definition 2·9(i) (which implies the sets
 $t_\gamma(v)$
are pairwise disjoint), and
 $\gamma$
is a functor since graphical maps respect the partial orders on embedding sets.
Given any graph G, there is an essentially unique active map from an n-star to G, where n is the size of the boundary
 $\eth(G)$
(see Examples 2·2 and 2·11). On the other hand, each vertex v determines an embedding
 $\iota_v \colon {\unicode{x2606}}_v \rightarrowtail G$
from a star, and any other map from an n-star classifying v is isomorphic to this one. It thus remains to show that the units of
 $\textbf{U}$
are precisely the stars.
If H is a graph which has a unique vertex and at least one internal edge, then there is the active map
 from above, and this map does not have an inert section since embeddings send internal edges to internal edges. Thus H is not a unit despite having
 $\gamma(H) \cong \langle{1}\rangle$
. On the other hand, if G is an arbitrary connected graph and
 is an active map, then since
 $\textbf{U}_{0}\subset \textbf{U}$
is a sieve ([
Reference Hackney, Robertson and Yau33
, proposition 5·2]), we deduce that
 $G \in \textbf{U}_{0}$
is a tree. (As in Remark C5, it is not possible for G to be the nodeless loop and have a map to
 ${\unicode{x2606}}_n$
, hence
 $\varphi$
is a map in
 $\textbf{U}$
.) By considering the generalised Reedy structure ([
Reference Hackney, Robertson and Yau33
, proposition 5·5]) on
 $\textbf{U}_{0}$
, we can conclude that
 $\varphi \in \textbf{U}_{0}^-$
and is a composition of codegeneracy maps. By inspection, this map has a unique inert section, hence
 ${\unicode{x2606}}_n$
is a unit.
The nilobjects of
 $\textbf{U}$
are the edges, while the nilobjects of
 $\widetilde{\textbf{U}}$
are the edges and the nodeless loops.
Remark 6·6 (Other graph categories). Each of the other graph categories considered in this paper (
 $\textbf{U}_{0}$
,
 $\textbf{U}_{\textrm{cyc}}$
,
 $\textbf{G}_{\textrm{sc}}$
 $\textbf{G}$
,
 $\textbf{U}_{/\mathfrak{o}}$
, and
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
) admits a functor to
 $\widetilde{\textbf{U}}$
sending an object to the corresponding (undirected) graph, as we see from Figure 2 of the introduction. Each of these becomes a hypermoment category by composing with
 $\gamma \colon \widetilde{\textbf{U}} \to \textbf{FinSet}_{\ast}^{\textrm{op}}$
. In all cases the units are again stars.
The graphical category
 $\textbf{U}$
is strongly unital in the sense of [
Reference Berger9
, definition 3·12]. This means that the full subcategory of
 $\textbf{U}_{\textrm{int}}$
on the units and nilobjects (that is, the stars and the edge) is dense, or in other words, every graph is a canonical colimit (in
 $\textbf{U}_{\textrm{int}}$
) of its vertex stars and its edges. The same is true for all of the other graph categories from Remark 6·6.
Remark 6·7. Though it is true that
 $\widetilde{\textbf{U}}$
and
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
are also strongly unital, the notion of Segal object we obtain from [
Reference Berger9
, 3·11] is different from what appeared in [
Reference Hackney, Robertson and Yau33
, definition 4·11], [
Reference Hackney, Robertson and Yau34
, notation 3·11], and [
Reference Hackney, Robertson and Yau31
, section 2·1] in the non-reduced case. In particular, if X is a strict Segal presheaf, in the second set of references the values of X on edges and nodeless loops will coincide, while in the first reference they may be distinct. This coincidence was necessary for establishing the nerve theorems for these categories (relating to modular operads, resp. wheeled properads).
Definition 6·8. A hypermoment category
 $\textbf{C}$
is extensional if, given a unit u, an active map

, and an inert map
 $u\rightarrowtail c$
, the pushout

exists in
 $\textbf{C}$
with
 $d \rightarrowtail d'$
inert, and is sent by
 $\gamma$
to a pushout in
 $\textbf{F}_{\ast}^{\textrm{op}}$
.
Example 6·9. The graphical category
 $\widetilde{\textbf{U}}$
is extensional. Indeed, suppose that
 $v \in G$
has valence n, and H is a graph with n-element boundary set. Then any active map
 gives a bijection between
 $\eth(H)$
and
 $nb(v) \cong \eth({\unicode{x2606}}_v)$
, so permits us to define a graph substitution
 $G\{H\}$
. This now fits into the diagram

where the bottom map is active and the right map is an embedding. We have
 $V_{G\{H\}} \cong (V_G \setminus \{v \}) \amalg V_H$
, and this allows one to show the preceding square is a pushout by producing explicit maps out of
 $G\{H\}$
using Definitions 2·9 and C4. Our square maps via
 $\gamma$
to the square

in
 $\textbf{FinSet}_\ast$
which is a pullback of finite sets since there is a bijection
 \begin{align*} (V_G\setminus \{v\}) \amalg V_H \cong \big\{ (v^{\prime},\ast) \mid v^{\prime}\in V_G \setminus \{v\} \big\} \amalg \big\{ (v,w) \mid w\in V_H \big\}.\end{align*}
The other categories of graphs from Remark 6·6 are extensional by a similar argument.
The following notion was introduced in [ Reference Chu and Haugseng13 , definition 2·1].
Definition 6·10. An algebraic pattern is an
 $\infty$
-category
 $\textbf{P}$
equipped with an inert-active factorisation system
 $(\textbf{P}_{\textrm{int}}, \textbf{P}_{\textrm{act}})$
, along with some specified full subcategory
 $\textbf{P}_{\textrm{el}} \subseteq \textbf{P}_{\textrm{int}}$
whose objects are called elementary. A morphism of algebraic patterns is a functor which preserves active maps, inert maps, and elementary objects.
The notion of factorisation system here reduces to that of orthogonal factorisation system when
 $\textbf{P}$
is a 1-category, which is our only case of interest in this paper.
Remark 6·11. Every hypermoment category
 $\textbf{C}$
yields two canonical choices for algebraic pattern structure on
 $\textbf{C}^{\textrm{op}}$
, depending only on the choice of elementary objects. If
 $(\textbf{C}_{\textrm{act}}, \textbf{C}_\textrm{int})$
is the factorisation system on
 $\textbf{C}$
, then we utilise the factorisation system
 $(\textbf{C}_\textrm{int}^{\textrm{op}}, \textbf{C}_\textrm{act}^{\textrm{op}})$
on
 $\textbf{C}^{\textrm{op}}$
. We use similar notation to [
Reference Chu and Haugseng13
, section 3].
-
(i) The elementary objects of the algebraic pattern
$\textbf{C}^{\textrm{op},\natural}$
are the units and the nilobjects of
$\textbf{C}$
. This is the choice made in [
Reference Berger9
, definition 3·12]. -
(ii) The elementary objects of the algebraic pattern
$\textbf{C}^{\textrm{op},\flat}$
are the units of
$\textbf{C}$
.


In what follows, we mostly consider the associated ‘natural’ algebraic pattern associated to the hypermoment categories under consideration. The exceptions are the categories
 $\widetilde{\textbf{U}}$
and
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
, where we will exclude nodeless loops from our set of elementary objects (following the reasoning in Remark 6·7). It is important that we do not work with the ‘flat’ algebraic pattern when comparing directed and undirected graphs, as the flat analogue of Theorem 6·23 does not hold.
Definition 6·12. Let
 $\textbf{C}$
be one of the graph categories under consideration, regarded as both a hypermoment category and the opposite of an algebraic pattern. We write
 $\textbf{C}_\textrm{el} \subseteq \textbf{C}_\textrm{int}$
for the full subcategory on the units/stars and the edges, which we call ‘elementary’ objects. We will write
 $\textbf{C}^\textrm{int}_{/c} \subseteq \textbf{C}_{/c}$
for the full subcategory of the slice on the inert maps with codomain c. Likewise, we write
 $\textbf{C}^\textrm{act}_{c/} \subseteq \textbf{C}_{c/}$
for the full subcategory on the coslice consisting of active maps with domain c. By the factorisation system, morphisms in
 $\textbf{C}^\textrm{int}_{/c}$
will also be inert maps (likewise, morphisms in
 $\textbf{C}^\textrm{act}_{c/}$
will be active maps). Finally, we write
 $\textbf{C}^\textrm{el}_{/c} := \textbf{C}_\textrm{el} \times_{\textbf{C}_\textrm{int}} \textbf{C}^\textrm{int}_{/c}$
for the category whose objects are inert maps with codomain c and elementary domain.
In this way, all of the graph categories appearing in Figure 2 of the introduction are hypermoment categories, either by the above or by [ Reference Berger9 ], and their opposites are algebraic patterns (many were listed in [ Reference Chu and Haugseng13 ]). Each of the indicated functors yields a morphism of algebraic patterns in the sense of Definition 6·10. Yet the point of this machinery is to study Segal objects, and morphisms of algebraic patterns are frequently poorly behaved with respect to such.
Definition 6·13. Let
 $\textbf{C}$
be one of our graph categories. A presheaf
 $Z \in \widehat{\textbf{C}}$
is Segal if, for each object
 $c\in \textbf{C}$
, the canonical map
 \begin{align*}Z_{c} \to \lim_{w \rightarrowtail c} Z_w\end{align*}
is an isomorphism, where the limit on the right is that for the composite
 \begin{align*} (\textbf{C}^{\textrm{el}}_{/c})^{\textrm{op}} \xrightarrow{dom} \textbf{C}^{\textrm{op}} \xrightarrow{Z} \textbf{Set}. \end{align*}
We emphasise once again that this notion differs from that of [
Reference Berger9
, 3·11] when
 $\textbf{C}$
is
 $\widetilde{\textbf{U}}$
or
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
, since we do not consider all nilobjects as elementary (see Remark 6·7 for an explanation).
Remark 6·14. A variety of nerve theorems say that the full subcategory of Segal presheaves is equivalent to the corresponding category of operadic structures. A summary of these (anticipated) results is included in the following table.

The categories
 $\textbf{U}_{0}$
and
 $\textbf{G}_{\textrm{sc}}$
have blanks in the table, as I am unaware of anyone establishing the relevant nerve theorems in these cases. One expects that both of these should follow from Weber’s abstract nerve theorem [
Reference Weber59
, section 4] (though this theorem does not apply to
 $\textbf{U}$
,
 $\textbf{G}$
,
 $\textbf{U}_{/\mathfrak{o}}$
). Further, the nerve theorem for augmented cyclic operads implies that for dioperads, as explained in [
Reference Hackney28
]. A closely related nerve theorem for the category
 $\boldsymbol{\Xi}$
and cyclic operads whose set of colors has a trivial involution appears in [
Reference Hackney, Robertson and Yau32
].
To simplify matters, we regard all vertical functors and the functor
 $\textbf{G} \to \textbf{U}_{/\mathfrak{o}}$
in Figure 2 as replete subcategory inclusions. The following lemma does not hold for
 $\textbf{G} \to \textbf{U}_{/\mathfrak{o}}$
essentially because
 $\operatorname{Emb}\!(G)$
and
 $\operatorname{sSb}\!(G)$
(used in the definition of
 $\textbf{G}$
in Appendix B) differ for many acyclic directed graphs G.
Lemma 6·15.
All displayed functors in Figure 2 of the introduction, with the exception of
 $\textbf{G} \to \textbf{U}_{/\mathfrak{o}}$
, are discrete fibrations.
Proof. For the four horizontal functors landing in the right-hand column, this follows from Remark 5·9 since given a map
 $\varphi \colon G \to G'$
of undirected graphs and an element
 $x' \in \mathfrak{o}_{G^{\prime}}$
, there is a unique element
 $x\in \mathfrak{o}_G$
so that
 $\varphi \colon (G,x) \to (G',x')$
is a morphism.
The vertical functors are all sieves, hence discrete fibrations.
Lemma 6·16.
If
 $f \colon \textbf{C} \to \textbf{D}$
is one of the functors appearing in Figure 2
, then
 \begin{align*} \textbf{C}^\textrm{el}_{/c} \to \textbf{D}^\textrm{el}_{/f(c)}\end{align*}
is an equivalence for each object
 $c\in \textbf{C}$
. In particular,
 $\textbf{C}^{\textrm{op}} \to \textbf{D}^{\textrm{op}}$
is a strong Segal morphism in the sense of [
Reference Chu and Haugseng13
].
Proof. The elementary objects in
 $\textbf{G}$
and
 $\textbf{U}_{/\mathfrak{o}}$
coincide, and if K is an elementary object and G is an arbitrary acyclic graph, then
 $\textbf{G}_\textrm{int}(K,G) \to (\textbf{U}_{/\mathfrak{o}})_\textrm{int}(K,G)$
is a bijection. It follows that
 $\textbf{G}^\textrm{el}_{/G} \to (\textbf{U}_{/\mathfrak{o}})^\textrm{el}_{/G}$
is an isomorphism.
For any of the other functors
 $f\colon \textbf{C} \to \textbf{D}$
, the bottom map of the following pullback is an isomorphism by Lemma 6·15, hence the top map is an isomorphism.

The previous lemma tells us, in particular, that restricting Segal presheaves gives us Segal presheaves (this is precisely the point of the definition of strong Segal morphism in [ Reference Chu and Haugseng13 ]).
Proposition 6·17.
Suppose
 $f \colon \textbf{C} \to \textbf{D}$
is one of the functors appearing in Figure 2 of the introduction. If
 $M \in \widehat{\textbf{D}}$
is Segal, then so is
 $f^*M \in \widehat{\textbf{C}}$
. If f is one of the functors
 \begin{align*} \boldsymbol{\Omega} \longrightarrow \textbf{U}_{\textrm{cyc}} \qquad \textbf{G}_{\textrm{sc}} \longrightarrow \textbf{U}_{0} \qquad \textbf{U}_{/\mathfrak{o}} \longrightarrow \textbf{U} \qquad \widetilde{\textbf{U}}_{/\mathfrak{o}} \longrightarrow \widetilde{\textbf{U}},\end{align*}
then if
 $M \in \widehat{\textbf{D}}$
is a presheaf and
 $f^*M \in \widehat{\textbf{C}}$
is Segal, then M is Segal.
Proof. Let c be an arbitrary object of
 $\textbf{C}$
. We have a commutative diagram

whose bottom map is an isomorphism by the equivalence
 $\textbf{C}^\textrm{el}_{/c} \simeq \textbf{D}^\textrm{el}_{/f(c)}$
from Lemma 6·16. If M is Segal, then the right-hand map in the square is a bijection, hence so is the left-hand map in the square. Thus
 $f^*M$
is Segal.
Now suppose that f is one of the four indicated functors, and that
 $f^*M$
is Segal. Let
 $d \in \textbf{D}$
be an arbitrary object; since f is surjective on objects, choose some
 $c\in \textbf{C}$
with
 $d=f(c)$
. Since the left-hand map in the above square is a bijection, so is the right-hand map, hence M is Segal as well.
Lemma 6·18.
If
 $f \colon \textbf{C} \to \textbf{D}$
is one of the functors appearing in Figure 2 of the introduction, with the exception of
 $\textbf{G} \to \textbf{U}_{/\mathfrak{o}}$
, then
 \begin{align*} \textbf{C}^\textrm{int}_{/c} \longrightarrow \textbf{D}^\textrm{int}_{/f(c)}\end{align*}
is an equivalence for each object
 $c\in \textbf{C}$
. In particular,
 $\textbf{C}^{\textrm{op}} \to \textbf{D}^{\textrm{op}}$
has unique lifting of inert morphisms in the sense of [
Reference Chu and Haugseng13
, definition 7·2].
Proof. In all of the categories, a map is inert if and only if it maps to an embedding in
 $\widetilde{\textbf{U}}$
. Thus in any of the discrete fibrations from Lemma 6·15, lifts of inert maps with codomain f(c) are also inert. The conclusion follows since the square

is a pullback, whose bottom map is an isomorphism by Lemma 6·15.
The previous lemma does not hold for
 $\textbf{G} \to \textbf{U}_{/\mathfrak{o}}$
, as not every embedding (with codomain an acyclic directed graph) is a convex inclusion (see Example B6).
Remark 6·19. Despite this unique lifting of inert morphisms, several of these functors will not be extendable morphisms of algebraic patterns in the sense of [ Reference Chu and Haugseng13 , definition 7·7] as condition (2) often fails (for instance, when going from simply-connected graphs to more general graphs).
6·1. Left Kan extension and Segality
In Proposition 6·17, we showed that restriction of presheaves behaves well with respect to the Segal condition. We now show that for functors going from directed to undirected graphs, the left Kan extension of presheaves has an appealing form. We use this to show that left Kan extension behaves well with respect to the Segal condition.
Lemma 6·20.
Let
 $f\colon \textbf{C} \to \textbf{D}$
be one of the forgetful functors
 \begin{align*}\textbf{G}_{\textrm{sc}} \longrightarrow \textbf{U}_{0} \qquad\textbf{U}_{/\mathfrak{o}} \longrightarrow \textbf{U} \qquad\widetilde{\textbf{U}}_{/\mathfrak{o}} \longrightarrow \widetilde{\textbf{U}}.\end{align*}
If
 $Z \in \widehat{\textbf{C}}$
is
 $\textbf{C}$
-presheaf, then the left Kan extension
 $f_!Z \in \widehat{\textbf{D}}$
may be described by the formula
 \begin{align*} (f_!Z)_G = \coprod_{x\in \mathfrak{o}_G} Z_{(G,x)}\end{align*}
and the action on a morphism
 $\varphi \colon H \to G$
of
 $\textbf{D}$
, is given on the
 $x\in \mathfrak{o}_G$
summand by the following:

Proof. It is a classical fact that left Kan extension along a Grothendieck opfibration may be computed by taking colimits over the fibers. The functor
 $\textbf{C}^{\textrm{op}} \to \textbf{D}^{\textrm{op}}$
is a discrete opfibration by Lemma 6·15, so the fibers
 $\mathfrak{o}_G$
are discrete, and the result follows.
Notice that a similar description of the right Kan extension as a product seems unlikely, as one cannot push forward orientations.
Remark 6·21. Recall the dendroidal category
 $\boldsymbol{\Omega}$
from Definition 5·11, which is a full subcategory of
 ${\textbf{U}_{\textrm{cyc}}}_{/\mathfrak{o}}$
. Let
 $f\colon \boldsymbol{\Omega} \to \textbf{U}_{\textrm{cyc}}$
be the forgetful functor. As in the preceding lemma, we have
 \begin{align*} (f_!Z)_T = \coprod_{r\in \eth(T)} Z_{(T,r)}, \end{align*}
where we are writing r for the unique orientation of T so that the chosen boundary element is the unique element of
 $\operatorname{out}\!(T) = \eth(T) \cap A_T^-$
and each
 $\operatorname{out}\!(v) = nb(v) \cap D_T^+$
is a singleton (see Remark 5·5). This formula is related to lemma 4·2 and definition 4·8 of [
Reference Drummond-Cole and Hackney19
], and is also closely related to section 2·1 of [
Reference Hackney, Robertson and Yau32
].
The following lemma will be used in the proof of Theorem 6·23, which states that
 $f_!$
preserves Segal objects.
Lemma 6·22.
Let
 $f\colon \textbf{C} \to \textbf{D}$
be one of the forgetful functors
 \begin{align*}\textbf{G}_{\textrm{sc}} \longrightarrow \textbf{U}_{0} \qquad\textbf{U}_{/\mathfrak{o}} \longrightarrow \textbf{U} \qquad\widetilde{\textbf{U}}_{/\mathfrak{o}} \longrightarrow \widetilde{\textbf{U}}.\end{align*}
If
 $Z \in \widehat{\textbf{C}}$
is a presheaf and
 $G\in \textbf{D}$
is an undirected graph, then the map
 \begin{equation} \coprod\limits_{x\in \mathfrak{o}_G} \lim\limits_{k \colon K \rightarrowtail G} Z_{(K,k^*x)} \longrightarrow \lim\limits_{k \colon K \rightarrowtail G} \coprod\limits_{y\in \mathfrak{o}_K} Z_{(K,y)} = \lim\limits_{k \colon K \rightarrowtail G} (f_!Z)_K\end{equation}
is a bijection, where the limits are taken over the opposite of
 $\textbf{D}^\textrm{el}_{/G}$
(in particular, each K is either an edge or a star).
Proof. For concreteness, we prefer to take a skeleton of
 $\textbf{D}^\textrm{el}_{/G}$
, with objects
 \begin{align*} \{ \iota_v \colon {\unicode{x2606}}_v \rightarrowtail G \mid v\in V_G \} \amalg \{ \kappa_e \colon {{\updownarrow}}_e \rightarrowtail G \mid e\in E_G \}\end{align*}
(see Example 2·5).
We first observe that
 $\mathfrak{o}$
from Definition 5·3 is Segal. This means that the function
 \begin{equation} \mathfrak{o}_G \longrightarrow \lim_{k\colon K \rightarrowtail G} \mathfrak{o}_K,\end{equation}
sending
 $x\in \mathfrak{o}_G$
to the element
 $(k^*x)$
, is a bijection. It is automatically an injection since the composite
 $\mathfrak{o}_G \to \lim_k \mathfrak{o}_K \to \prod_{\kappa_e} \mathfrak{o}_{{{\updownarrow}}_e}$
is a bijection, as both
 $\mathfrak{o}_G$
and
 $\prod_{\kappa_e} \mathfrak{o}_{{{\updownarrow}}_e}$
are isomorphic to the set of involutive maps
 $A_G \to \{+1,-1\}$
. On the other hand, if
 $(y^k) \in \lim_k \mathfrak{o}_K$
, then by using the bijection
 $\mathfrak{o}_G \cong \prod_{\kappa_e} \mathfrak{o}_{{{\updownarrow}}_e}$
we obtain
 $x \in \mathfrak{o}_G$
with
 $\kappa_e^* x = y^{\kappa_e}$
for all
 $e\in E_G$
. We wish to show that
 $k^* x = y^k$
for all
 $k\in \textbf{D}^\textrm{el}_{/G}$
. If G does not have any vertices, then we are done. Otherwise, let v be a vertex. For each
 $d\in nb(v) = D_{{\unicode{x2606}}_v}$
spanning an edge
 $e \in E_G$
, there is an embedding
 $j_d \colon {{\updownarrow}}_e \rightarrowtail {\unicode{x2606}}_v$
sending d to d and making the following triangle commute:

Then
 $j_d^*(y^{\iota_v}) = y^{\kappa_e} = \kappa_e^* x = j_d^*(\iota_v^*x)$
. Since
 $\mathfrak{o}_{{\unicode{x2606}}_v} \cong \prod_{nb(v)} \mathfrak{o}_{{{\updownarrow}}_e}$
, we conclude that
 $y^{\iota_v} = \iota_v^*x$
. We have now established that
 $y^k = k^* x$
for all
 $k\in \textbf{D}^\textrm{el}_{/G}$
, proving that (6·2) is a bijection.
Elements on the left-hand side of (6·1) are of the form
 $(x,(z^k))$
where
 $x\in \mathfrak{o}_G$
and
 $z^k \in Z_{(K, k^*x)}$
for each
 $k\colon K \rightarrowtail G$
in
 $\textbf{D}^\textrm{el}_{/G}$
. These are subject to the compatibility condition
 $j^*(z^k) = z^{kj}$
whenever
 $j \colon K' \rightarrowtail K$
is an embedding. Likewise, elements on the right-hand side of (6·1) are of the form
 $(y^k,s^k)$
with
 $y^k \in \mathfrak{o}_K$
,
 $s^k \in Z_{(K,y^k)}$
for each
 $k\colon K \rightarrowtail G$
in
 $\textbf{D}^\textrm{el}_{/G}$
. These are subject to the compatibility conditions
 $j^*(y^k) = y^{kj}$
and
 $j^*(s^k) = s^{kj}$
whenever
 $j \colon K' \rightarrowtail K$
is an embedding. The map (6·1) takes
 $(x, (z^k))$
to
 $(k^*x, z^k)$
. Bijectivity of (6·1) follows from that of (6·2).
Theorem 6·23.
Let
 $f\colon \textbf{C} \to \textbf{D}$
be one of the forgetful functors
 \begin{align*}\textbf{G}_{\textrm{sc}} \longrightarrow \textbf{U}_{0} \qquad\textbf{U}_{/\mathfrak{o}} \longrightarrow \textbf{U} \qquad\widetilde{\textbf{U}}_{/\mathfrak{o}} \longrightarrow \widetilde{\textbf{U}}.\end{align*}
Then the functor
 $f_! \colon \widehat{\textbf{C}} \to \widehat{\textbf{D}}$
preserves Segal objects.
Proof. Let
 $Z\in \widehat{\textbf{C}}$
be a Segal object, that is, suppose that
 \begin{align*} Z_{(G,x)} \longrightarrow \lim_{(\textbf{C}^\textrm{el}_{/(G,x)})^{\textrm{op}}} Z_{(K,y)}\end{align*}
is a bijection for each
 $(G,x)\in \textbf{C}$
. We know that
 $\textbf{C}^\textrm{el}_{/(G,x)} \to \textbf{D}^\textrm{el}_{/G}$
is an equivalence by Lemma 6·16, so this becomes
 \begin{align*} Z_{(G,x)} \cong \lim_{k \colon K \rightarrowtail G} Z_{(K,k^*x)}\end{align*}
instead, where K ranges over elementary objects of
 $\textbf{D}$
. The function
 \begin{equation} (f_!Z)_G \longrightarrow \lim_{k \colon K \rightarrowtail G} (f_!Z)_K\end{equation}
is such that the following diagram commutes for every
 $x_0$
in
 $\mathfrak{o}_G$
and
 $k_0$
in
 $\textbf{D}^\textrm{el}_{/G}$
:

Applying Lemma 6·22, we see that (6·3) is a bijection, hence
 $f_!Z$
is Segal.
This proof (including the corresponding statement for Lemma 6·22) can be readily adapted by using Remark 6·21 in place of Lemma 6·20 to give the following.
Proposition 6·24.
If f is the functor
 $\boldsymbol{\Omega} \to \textbf{U}_{\textrm{cyc}}$
that forgets about the directed structure, then
 $f_! \colon \widehat{\boldsymbol{\Omega}} \to \widehat{\textbf{U}_{\textrm{cyc}}}$
takes Segal objects to Segal objects.
Remark 6·25. Theorem 6·23 (and Proposition 6·24) can also be recovered from a theorem of Haugseng–Kock [
Reference Haugseng and Kock35
], which concerns a left fibration over an algebraic pattern whose unstraightening is Segal. We briefly explain this alternate method. We know that
 $\textbf{C}^{\textrm{op}} \to \textbf{D}^{\textrm{op}}$
is a discrete opfibration Lemma 6·15 and
 $\mathfrak{o}$
is Segal by Lemma 6·22. Proposition 3·2·5 of [
Reference Haugseng and Kock35
] implies that left Kan extension along f induces an equivalence of
 $\infty$
-categories
 \begin{equation} \textrm{Seg}_{\textbf{C}^{\textrm{op}}}(\textbf{Space}) \xrightarrow{\sim} \textrm{Seg}_{\textbf{D}^\textrm{op}}(\textbf{Space})_{/\mathfrak{o}}, \end{equation}
where
 $\textbf{Space}$
denotes the
 $\infty$
-category of spaces. The full subcategory of
 $\widehat{\textbf{C}}$
on the Segal objects is equivalent to the subcategory of discrete objects of
 $\textrm{Seg}_{\textbf{C}^\textrm{op}}(\textbf{Space})$
by [
Reference Beardsley and Hackney8
, lemma 1·12]. The equivalence (6·4) above preserves discrete objects, and since
 $\mathfrak{o}$
is discrete,
 $\textrm{Seg}_{\textbf{D}^{\textrm{op}}}(\textbf{Space})_{/\mathfrak{o}} \to \textrm{Seg}_{\textbf{D}^\textrm{op}}(\textbf{Space})$
preserves discrete objects as well [
Reference Lurie45
, lemma 5·5·6·14]. We now have that left Kan extension along f restricts to a functor
 $\textrm{Seg}_{\textbf{C}^\textrm{op}}(\textbf{Space}) \to \textrm{Seg}_{\textbf{D}^{\textrm{op}}}(\textbf{Space})$
which preserves discrete objects, so
 $\widehat{\textbf{C}} \to \widehat{\textbf{D}}$
preserves Segal objects. The argument for Proposition 6·24 (where
 $f\colon \textbf{C} \to \textbf{D}$
is
 $\boldsymbol{\Omega} \to \textbf{U}_{\textrm{cyc}}$
) is analogous, using the rooting presheaf instead of
 $\mathfrak{o}$
.
Appendix A. Categories of trees for cyclic operads
In this section we specialise Definition 4·2 to the case when the codomain G ′ is simply-connected, which implies that the domain is also a tree by [Reference Hackney, Robertson and Yau33, proposition 5·2]. The resulting categories of graphs are related to cyclic operads [Reference Getzler and Kapranov26] and higher cyclic operads [Reference Hackney, Robertson and Yau32, Reference Walde58]. Our goal is to give a description of new graph maps between trees that is mirrors the ‘complete morphisms’ from definition 1·12 of [Reference Hackney, Robertson and Yau32]. This description appears as Theorem A7 below.
In this section, all graphs are undirected.
Definition A1 (Paths and trees). Let G be a graph.
-
(i) A path in G is a finite alternating sequence of edges and vertices of G so that if e and v are adjacent then some arc of e appears in nb(v), and so that the pattern vev can only appear in the path if both arcs of e are in nb(v).
-
(ii) A cycle is a path of length strictly greater than one that begins and ends at the same edge or same vertex.
-
(iii) The graph G is a tree if and only if it is connected and does not have any paths which are cycles.
We write
 $\textbf{U}_{0} \subset \textbf{U}$
for the full subcategory on the trees, and
 $\textbf{U}_{\textrm{cyc}} \subset \textbf{U}_{0}$
for the full subcategory consisting of those trees with non-empty boundary.
Note that a graph G is a tree just when its associated topological space is simply-connected. A graph G is connected if and only if for each pair
 \begin{align*} (x_1,x_2) \in (V_G \amalg E_G)^{\times 2},\end{align*}
there is a path containing both
 $x_1$
and
 $x_2$
.
Lemma A2.
If T is a tree and
 $f \colon H \rightarrowtail T$
is an embedding, then
 $A_H \to A_T$
is injective.
Proof. Suppose
 $a_1 \neq a_2$
are distinct arcs of H with
 $f(a_1) = f(a_2)$
. Without loss of generality, by Lemma 2·14 we may suppose that
 $a_1, a_2^\dagger \in \eth(H)$
and
 $a_1^\dagger, a_2 \in D_H$
(in particular, H is not an edge). Since H is connected, there exists a path
 \begin{align*} P = e_0 v_1 e_1 v_2 e_2 \dots v_n e_n\end{align*}
in H from
 $e_0 = [a_1,a_1^\dagger]$
to
 $e_n = [a_2, a_2^\dagger]$
. Since
 $a_1 \neq a_2^\dagger$
(equality would imply that
 $f(a_1)$
is a
 $\dagger$
-fixed point of
 $A_T$
), we know
 $e_0 \neq e_n$
so it follows that
 $n\geq 1$
. There is an associated path fP of T obtained by applying f to each edge and vertex. Since
 $fe_0 = fe_n$
, the path fP is a cycle, which is impossible since T is a tree.
In an arbitrary graph G, elements in
 $\operatorname{Emb}\!(G)$
are not necessarily uniquely determined by their boundary (for example, consider f and fk from example 1·23 of [
Reference Hackney, Robertson and Yau33
]). This complication disappears when G is a tree.
Lemma A3.
If T is a tree, then
 $\eth \colon \operatorname{Emb}\!(T) \to \wp(A_T)$
is injective.
Proof. By Lemma 2·15, the only way this can fail is if there is a pair h, k consisting of an embedding
 $h \colon H \rightarrowtail T$
where H contains at least one vertex and an embedding
 $k \colon K \rightarrowtail T$
where K is an edge, satisfying
 $\eth(h) = \eth(k)$
. This implies that
 $\eth(H) = \{ b_0, b_1 \}$
has two elements and
 $h(b_0)^\dagger = h(b_1)$
. Since
 $b_0^\dagger \in D_H$
it cannot be equal to
 $b_1$
, hence h is not injective. This is prohibited by Lemma A2.
Definition A4. Suppose T is a tree. A subtree S of T is a triple of subsets
 $A_S \subseteq A_T$
,
 $D_S \subseteq D_T$
, and
 $V_S \subseteq V_T$
so that the following hold.
-
(i) There is a commutative diagram as displayed

whose vertical maps are the inclusions and whose right square is a pullback.
-
(ii) The graph S is connected.
Each subtree of T determines an embedding, and by Lemma A2 any embedding
 $h\colon H \rightarrowtail T$
determines a subtree using the subsets
 $h(A_H), h(D_H)$
, and
 $h(V_H)$
. This produces a bijection between the set of subtrees of T and the set
 $\operatorname{Emb}\!(T)$
. In light of this, we use the following shorthand.
Notation A5. Suppose that S and T are trees and
 $\hat \varphi \colon \operatorname{Emb}\!(S) \to \operatorname{Emb}\!(T)$
is a function. If R is a subtree of S, we will write
 $\hat \varphi(R)$
for the subtree of T associated to the element
 $\hat \varphi [R \to S] \in \operatorname{Emb}\!(T)$
.
Remark A6. (Uniqueness of unions). Suppose R and S are two subtrees of T. We say that R and S overlap if
 $R\cap S$
(meaning the triple
 $(A_R \cap A_S, D_R \cap D_S, V_R \cap V_S)$
) is non-empty. As in [
Reference Hackney, Robertson and Yau32
, section 1·2], the graphs
 $R\cap S$
and
 $R\cup S$
are connected, and hence subtrees, if and only if R and S overlap. Unions in the sense of Definition 3·1 are unique in this context, and coincide with the union of subtrees.
We now turn to our desired characterisation of graphical maps between trees. By proposition 5·2 of [
Reference Hackney, Robertson and Yau33
],
 $\textbf{U}_{0}$
is a sieve in
 $\textbf{U}$
, so any graphical map with codomain a tree also has a tree as its domain.
Theorem A7.
Suppose that G and G′ are trees, and
 $\varphi = (\varphi_0,\hat \varphi)$
is a pair consisting of an involutive function
 $\varphi_0 \colon A_G \to A_{G^{\prime}}$
and a function
 $\hat \varphi \colon \operatorname{Emb}\!(G) \to \operatorname{Emb}\!(G')$
which satisfy condition (iv) of Definition 4·2. Then
 $\varphi$
is a new graph map if and only if
-
(v) If two subtrees S, T of G overlap, then so do
$\hat \varphi (S)$
and
$\hat \varphi (T)$
. In this case, we have:-
(a)
$\hat \varphi(S\cap T) = \hat\varphi(S) \cap \hat \varphi(T)$
and -
(b)
$\hat \varphi(S\cup T) = \hat\varphi(S) \cup \hat \varphi(T)$
.
-


Proof. In this proof, (i)–(iv) refer to the conditions from Definition 4·2.
Suppose
 $\varphi$
is a new graph map and let S and T be overlapping subtrees of G. As
 $\hat\varphi$
preserves order, we have the following subtrees

which implies that
 $\hat\varphi(S)$
and
 $\hat\varphi(T)$
overlap.
In the next two paragraphs, we will write
 ${\unicode{x2606}}'_{\!\!v}$
for the subtree containing the single vertex v. (That is,
 ${\unicode{x2606}}'_{\!\!v}$
is the subtree associated to the embedding
 $\iota_v \colon {\unicode{x2606}}_v \rightarrowtail G$
.)
To show that (a) holds, first note that
 $\hat\varphi(S\cap T)$
is a subtree of
 $\hat\varphi(S) \cap \hat\varphi(T)$
. To show these are equal, it suffices to show that every vertex in
 $\hat\varphi(S) \cap \hat\varphi(T)$
is also in
 $\hat\varphi(S\cap T)$
. But if v is vertex in
 $\hat\varphi(S) \cap \hat\varphi(T)$
, then we can find unique vertices
 $u\in V_S \subseteq V_G$
and
 $w\in V_T \subseteq V_G$
so that v is in
 $\hat \varphi ({\unicode{x2606}}'_{\!\!u})$
and in
 $\hat \varphi ({\unicode{x2606}}'_{\!\!w})$
. By (iii) the equality
 $u = w$
holds, so v is in
 $\hat\varphi(S\cap T)$
.
To see that (b) holds, note that
 $\hat \varphi(S) \cup \hat\varphi(T)$
is a subtree of
 $\hat \varphi(S\cup T)$
. Given a vertex v of
 $\hat \varphi(S\cup T)$
there is a unique vertex
 $u \in V_{S\cup T} \subseteq V_G$
with v in
 $\hat\varphi ({\unicode{x2606}}'_{\!\!u})$
. If u is in S, then v is in
 $\hat\varphi(S)$
, and if u is in T then v is in
 $\hat \varphi(T)$
. Hence the subtree
 $\hat \varphi(S) \cup \hat\varphi(T)$
contains all vertices of
 $\hat \varphi(S\cup T)$
, so these are equal.
Now suppose
 $\varphi$
satisfies conditions (iv) and (v). Condition (ii) follows immediately from (b).
We next address (i), which says that
 $\hat \varphi$
sends edges to edges. If T is an edge of G consisting of the arcs
 $a,a^\dagger$
, then by (iv) the boundary of
 $\hat \varphi (T)$
is the set
 $\{ \varphi_0(a), \varphi_0(a^\dagger) \}$
. There is only one subtree having this boundary by Lemma A3, namely the edge consisting of the arcs
 $\{ \varphi_0(a), \varphi_0(a)^\dagger \}$
. Thus (i) holds.
Suppose

are subtrees of G with
 $V_{S^{\prime}} \cap V_{T}$
empty. Our goal is to show that
 $\hat \varphi (S')$
and
 $\hat \varphi (T)$
are vertex disjoint. If either of T or S
′ is an edge then the same is true for
 $\hat \varphi (T)$
or
 $\hat \varphi (S')$
by (i), in which case
 $\hat \varphi(S')$
and
 $\hat \varphi(T)$
are vertex disjoint. We thus suppose that both S
′ and T contain a vertex. Consider the subset
 $\mathfrak{X}$
of
 $\operatorname{Emb}\!(G)$
consisting of those subtrees R with
 $V_R \cap V_T$
empty and
 $S' \subseteq R$
. Since
 $\mathfrak{X}$
is inhabited, we choose a maximal element
 $S\in \mathfrak{X}$
and then argue that the set
 $\eth(S) \cap A_T$
is inhabited. Suppose
 $\eth(S) \cap A_T$
is empty. If
 $a \in \eth(S) \cap D_G \subset D_G \setminus D_T$
, then t(a) is in
 $V_G \setminus (V_S \cup V_T)$
, contradicting maximality of S. We conclude that
 $\eth(S) \cap D_G$
must also be empty, hence
 $\eth(S) \subseteq \eth(G)$
. By Lemma 2·16 this implies that
 $S = G$
, hence
 $T\subseteq S$
, a contradiction to vertex disjointness.
Taking this S and T, we have
 $S\cap T$
is an edge and thus the same is true for
 $\hat \varphi(S \cap T)$
by (i). Using (a), we have
 \begin{align*} \hat \varphi(S \cap T) = \hat \varphi(S) \cap \hat \varphi(T) \supseteq \hat \varphi(S') \cap \hat \varphi(T),\end{align*}
so
 $\hat \varphi(S')$
and
 $\hat \varphi(T)$
are vertex disjoint. Thus (iii) holds.
This theorem makes wholly transparent the functor
 $\textbf{U}_{\textrm{cyc}} \to \boldsymbol{\Xi}$
into the category of trees from [
Reference Hackney, Robertson and Yau32
, definition 1·12].
Appendix B. Acyclic graphs and the properadic graphical category
In this section, we turn to the connected directed graphs which are acyclic (from now on only in the directed sense) and control properads. Properads were introduced by Vallette in his thesis [ Reference Vallette57 ] and, independently and in the form we use them, under the name compact symmetric polycategories in Duncan’s thesis [ Reference Duncan21 ]. Properads are the connected parts of props [ Reference Mac Lane46 ].
One major goal is to prove Theorem B18, which characterizes the properadic graphical category
 $\textbf{G}$
from Definition B9 as a particular subcategory of
 $\textbf{U}_{/\mathfrak{o}}$
, giving a more explicit description of theorem 9·66 from [
Reference Hackney, Robertson and Yau29
].
Example B1. A connected directed graph L is linear if each vertex has exactly one input and one output, and if the graph itself has exactly one input and one output. We write
 ${{\updownarrow}}_i \rightarrowtail L$
(resp.
 ${{\updownarrow}}_o \rightarrowtail L$
) for the embedding classifying the unique input (resp. output) edge.
Definition B2. Let G be a directed graph.
-
(i) A directed path in G is a map
$L \to G$
in the functor category
$\textbf{FinSet}^{\mathscr{G}}$
. -
(ii) A directed cycle is G is a path
$L\to G$
from a non-edge graph L so that the two composites
${{\updownarrow}}_i \rightarrowtail L \to G$
and
${{\updownarrow}}_o \rightarrowtail L \to G$
are equal. -
(iii) The graph G is acyclic if and only if it is connected (as an undirected graph) and it does not have any cycles.


The reader who compares this definition with Definition A1 will notice that here we require our directed paths start and end at edges, rather than possibly at vertices. When discussing directed graphs, acyclicity will always refer to this directed notion, rather than asking that the underlying undirected graph is a tree (which of course implies acyclicity).
Warning B3 (Regarding Appendix C). In this section, we do not utilize the extended directed graphs from Definition C7, and all directed graphs are as in Definition 5·1. We should morally regard the directed nodeless loops from Example C9 as having a cycle, but it is easier to exclude them from the discussion entirely.
Notice that if H has a cycle and
 $H \to G$
is any map in
 $\textbf{FinSet}^{\mathscr{G}}$
, then G has a cycle as well. Hence any embedding with acyclic codomain also has acyclic domain.
Item (1) in the following is the same concept as [ Reference Kock43 , 1·6·5], but restricted to the connected graphs.
Definition B4. Let G be an acyclic directed graph.
-
(1) We say an embedding
$h\colon H \rightarrowtail G$
is a convex inclusion if-
(a) it is injective, and
-
(b) it has the right lifting property in
$\textbf{FinSet}^{\mathscr{G}}$
with respect to the maps as L ranges over the linear graphs from Example B1.
\begin{align*} \downarrow_i \amalg \downarrow_o \to L\end{align*}
-
-
(2) A unstructured subgraph H of G is a pair of subsets
$E_H \subseteq E_G$
and
$V_H \subseteq V_G$
so that Then H is a graph by defining
\begin{align*} \bigcup_{v\in V_H} \big[ \operatorname{in}\!(v) \cup \operatorname{out}\!(v) \big] \subseteq E_H.\end{align*}
$I_H := \bigcup_{V_H} \operatorname{in}\!(v)$
and
$O_H := \bigcup_{V_H} \operatorname{out}\!(v)$
and the subset inclusions constitute an étale map
$H \to G$
.
-
(3) We write
$\operatorname{sSb}\!(G) \subseteq \operatorname{Emb}\!(G)$
for set of equivalence classes which represent convex inclusions, and call the elements of
$\operatorname{sSb}\!(G)$
structured subgraphs of G. That is, given a convex inclusion
$h\colon H' \rightarrowtail G$
, the subsets
$E_{H^{\prime}} \cong h(E_{H^{\prime}}) \subseteq E_G$
and
$h(V_{H^{\prime}})\subseteq V_G$
determine an unstructured subgraph H whose inclusion is isomorphic to h. We will use the notation
$H\in \operatorname{sSb}\!(G)$
for such a structured subgraph.


The terminology of structured subgraphs agrees with Definition 2·2·2 (via Remark 2·2·4) of [ Reference Chu and Hackney11 ]. These were called convex open subgraphs in [ Reference Kock43 , 1·6·5] and subgraphs in [ Reference Hackney, Robertson and Yau29 , definition 6·32].
A subgraph which is not structured.

Remark B5. The acyclicity of a directed graph G typically depends on its directed structure. Further, the set of structured subgraphs
 $\operatorname{sSb}\!(G)$
also depends on this structure, while the set of embeddings
 $\operatorname{Emb}\!(G)$
does not.
Example B6.
-
(i) Every edge and every vertex determines a structured subgraph (see Example 2·5). Hence we have the following commutative diagram:
-
(ii) The graph G is itself in
$\operatorname{sSb}\!(G)$
. -
(iii) The subgraph in Figure 8, with all edges pointing down, is not a structured subgraph as there is no directed path from
$e_0$
to
$e_1$
.


Remark B7. If H and K are unstructured subgraphs of G, then their union
 $H\cup K$
with
 \begin{align*} E_{H \cup K} &= E_H \cup E_K \subseteq E_G \\[5pt] V_{H \cup K} &= V_H \cup V_K \subseteq V_G\end{align*}
is also an unstructured subgraph of G. If H and K are two structured subgraphs of G, then
 $H\cup K$
may or may not be a structured subgraph. One obvious possiblity for failure is that
 $H\cup K$
may be disconnected, but even if it is connected its inclusion may not be convex. (Figure 8 provides one example, by taking H to be spanned by the valence three vertices, and K to be spanned by the valence four vertex.) We will write
 $H\cup K \in \operatorname{sSb}\!(G)$
when this union happens to be a structured subgraph.
If H, K are structured subgraphs of G, then they may have several unions when considered as elements of
 $\operatorname{Emb}\!(G)$
. But there is at most one union that is again a structured subgraph.
Lemma B8.
Suppose
 $H,K\in \operatorname{sSb}\!(G)$
, write h and k for the two inclusions, and let
 $U \subseteq \operatorname{Emb}\!(G)$
denote the set of all unions of h and k (in the sense of Definition 3·1). If U is inhabited, then
 $U \cap \operatorname{sSb}\!(G) = \{ [H \cup K \rightarrowtail G] \}$
.
Proof. If
 $H\cup K \in \operatorname{sSb}\!(G)$
then the inclusion
 $H \cup K \rightarrowtail G$
is an upper bound for h and k and by Remark B7 we know
 $V_{H\cup K} = V_H \cup V_K$
, so the inclusion is a union.
Now suppose
 $J \in \operatorname{sSb}\!(G)$
and the inclusion
 $J \rightarrowtail G$
is a union of the inclusions h and k. By Definition 3·1(2), we know that
 $V_J = V_H \cup V_K,$
hence
 $V_J = V_{H\cup K}$
. Further, we have
 $H \rightarrowtail J \rightarrowtail G$
and
 $K \rightarrowtail J \rightarrowtail G$
, so
 $E_H \cup E_K \subseteq E_J$
. If J is an edge, then this must be an equality. If J is not an edge, then every
 $e\in E_J$
is incident to some vertex
 $v \in V_J = V_{H\cup K}$
, hence must already be in
 $E_H \cup E_K$
. Thus
 $E_{H\cup K} = E_J$
, so we conclude that
 $H \cup K = J$
.
Now that we have structured subgraphs and their unions, we can present the version of the properadic graphical category that appeared in definitions 2·2·11 and 2·2·14 of [ Reference Chu and Hackney11 ].
Definition B9. The properadic graphical category, denoted
 $\textbf{G}$
, has objects the acyclic directed graphs. A morphism
 $\varphi \colon G \to G'$
consists of two functions
 $\bar\varphi_0 \colon E_G \to E_{G^{\prime}}$
and
 $\check \varphi \colon \operatorname{sSb}\!(G) \to \operatorname{sSb}\!(G')$
so that the following hold.
-
(1) The diagram
commutes.
-
(2) Suppose that
$H_1, H_2 \in \operatorname{sSb}\!(G)$
. If
$H_1 \cup H_2 \in \operatorname{sSb}\!(G)$
, then
$\check \varphi(H_1 \cup H_2) = \check \varphi(H_1) \cup \check \varphi (H_2)$
.


Composition in
 $\textbf{G}$
is given by composition of pairs.
The equivalence with the original definition of the properadic graphical category from [ Reference Hackney, Robertson and Yau29 ] is proved in theorem A·1 of [ Reference Chu and Hackney11 ].
Our goal is to prove Theorem B18, which characterises
 $\textbf{G}$
as a subcategory of
 $\textbf{U}_{/\mathfrak{o}}$
. We give a proof that does not directly rely on the notions of properad or wheeled properad, instead relying on properties of graphs and the notions developed here. It is also possible to prove this using (wheeled) properads, by comparing the two notions of subgraph from sections 6·3·2 and 9·4·1 of [
Reference Hackney, Robertson and Yau29
].
We begin by exhibiting a function
 $\textbf{G}(G,G') \to \textbf{U}_{/\mathfrak{o}}(G,G')$
which we later prove (in Theorem B18) is part of an injective-on-objects functor.
Proposition B10.
Suppose
 $\varphi = (\bar \varphi_0, \check \varphi) \colon G \to G'$
is a properadic graphical map between two acyclic directed graphs. Then
 $\varphi$
determines graphical map in
 $\textbf{U}_{/\mathfrak{o}}$
using
 $\varphi_0 = \varphi_0^- \amalg \varphi_0^+ \colon A_G \to A_{G^{\prime}}$
defined as follows

and using the composite function

Proof. One checks the conditions of Definition 2·9. Condition (i) is known for properadic graphical maps using the definition in [ Reference Hackney, Robertson and Yau29 ]. Condition (ii) follows from Definition B9(1).
If
 $\eth(G) = \varnothing$
, then since G is acyclic there must be some vertex v so that at least one of
 $\operatorname{in}\!(v)$
or
 $\operatorname{out}\!(v)$
is not a one-element set. Hence condition (iii) holds.
The following useful proposition appears as corollary 6·62 of [ Reference Hackney, Robertson and Yau29 ].
Proposition B11.
The forgetful functor
 $\textbf{G} \to \textbf{Set}$
that sends G to
 $E_G$
and
 $\varphi$
to
 $\bar \varphi_0$
is faithful.
Remark B12. In the definition of properadic graphical maps
 $\varphi \colon G \to G'$
, we could have forgotten about the function
 $\bar \varphi_0$
had we been willing to add an additional axiom on
 $\check \varphi$
:
-
(0) The function
$\check \varphi \colon \operatorname{sSb}\!(G) \to \operatorname{sSb}\!(G')$
sends edges to edges.

Indeed, doing so would let us define
 $\bar \varphi_0$
to fit into the following diagram

In the original definition, (0) is a consequence of (1).
Lemma B13.
Suppose
 $k \colon K \rightarrowtail G$
is an embedding in
 $\textbf{U}_{/\mathfrak{o}}$
. If
 $k(e) = k(e')$
for distinct edges
 $e,e'\in E_K$
, then k(e) is an internal edge of G and one of e or e′ is in
 $\operatorname{in}\!(K)$
while the other is in
 $\operatorname{out}\!(K)$
. As a consequence, if
 $k(\!\operatorname{in}\!(K)) \subseteq \operatorname{in}\!(G)$
or
 $k(\!\operatorname{out}\!(K)) \subseteq \operatorname{out}\!(G)$
, then k is injective.
Lemma B14.
Suppose J and G are acyclic directed graphs, J has two vertices
 $V_J = \{ u , v\}$
, and
 is an active map in
 $\textbf{U}_{/\mathfrak{o}}$
. Then
 \begin{align*} \psi_1(u), \psi_1(v)\in \operatorname{sSb}\!(G) \subseteq \operatorname{Emb}\!(G).\end{align*}
Proof. Notice that exactly one of the sets
 $\operatorname{in}\!(u) \cap \operatorname{out}\!(v)$
and
 $\operatorname{in}\!(v) \cap \operatorname{out}\!(u)$
is inhabited, for otherwise J would have a directed cycle or be disconnected. Without loss of generality, we suppose that the first of these is empty, that is, we suppose
 $\operatorname{in}\!(u) \subseteq \operatorname{in}\!(J)$
,
 $\operatorname{out}\!(v) \subseteq \operatorname{out}\!(J)$
, and
 $\operatorname{in}\!(v) \cap \operatorname{out}\!(u) \neq \varnothing$
.
We first show that
 $\psi_1(u)$
and
 $\psi_1(v)$
are injective, hence represented by inclusions of unstructured subgraphs
 $K_u$
and
 $K_v$
. Write
 $\psi_u \colon K'_{\!\!u} \rightarrowtail G$
for a representative of
 $\psi_1(u)$
. Since
 $\psi_u (\!\operatorname{in}\! (K'_{\!\!u})) = \bar \psi_0 (\!\operatorname{in}\!(u)) \subseteq \bar \psi_0 (\!\operatorname{in}\!(J)) = \operatorname{in}\!(G)$
, by Lemma B13 we have
 $\psi_u$
is injective. We write
 $K_u \rightarrowtail G$
for the associated inclusion of (unstructured) subgraphs, and likewise
 $\psi_1(v) = [K_v \rightarrowtail G]$
.
If
 $K_u$
is an edge (necessarily in the set
 $\operatorname{in}\!(G)$
), then since the unique element of
 $\operatorname{out}\!(u)$
is a member of the set
 $\operatorname{in}\!(v)$
, the function
 $\bar\psi_0$
gives bijections
 $\operatorname{in}\!(v) \cong \operatorname{in}\!(G)$
and
 $\operatorname{out}\!(v) = \operatorname{out}\!(J) \cong \operatorname{out}\!(G)$
, hence
 $K_v = G$
. Likewise, if
 $K_v$
is an edge then
 $K_u = G$
; in either case
 $K_u$
and
 $K_v$
are both in
 $\operatorname{sSb}\!(G)$
.
We now suppose each of
 $K_u$
and
 $K_v$
has a vertex. If
 $e\in E_{K_v}$
, we now show that there does not exist a vertex w of
 $K_u$
with
 $e\in \operatorname{in}\!(w)$
. Suppose, to the contrary, that
 $e\in \operatorname{in}\!(w)$
for some
 $w\in V_{K_u}$
. Then since
 $e\in E_{K_u}$
, it is also an element of
 \begin{align*} E_{K_u} \cap E_{K_v} = (\!\operatorname{in}\!(K_u) \cup \operatorname{out}\!(K_u)) \cap (\!\operatorname{in}\!(K_v) \cup \operatorname{out}\!(K_v))\end{align*}
since
 $K_u$
and
 $K_v$
are vertex disjoint. But
 $e\notin \operatorname{out}\!(K_u)$
, hence
 $e\in \operatorname{in}\!(K_u) \subseteq \operatorname{in}\!(G)$
. Since G contains a vertex,
 $e\notin \operatorname{out}\!(G) \supseteq \operatorname{out}\!(K_v)$
, hence
 $e\in \operatorname{in}\!(K_v)$
. As
 $K_v$
was assumed to contain a vertex, this tells us
 $w \in V_{K_v}$
, which is impossible since
 $K_u$
and
 $K_v$
are vertex disjoint.
As a consequence of the previous paragraph, if P is any path in G from one edge of
 $K_v$
to another, then every vertex and every edge on this path must also be in
 $K_v$
. We conclude by Definition B4 that
 $K_v$
is a structured subgraph of G, and a flipped argument shows that
 $K_u$
is a structured subgraph of G as well.
Lemma B15.
Let H be an acyclic directed graph with at least two vertices, let
 $u\in V_H$
be an almost isolated vertex [
Reference Hackney, Robertson and Yau29
, definition 2·60] and let
 $J \in \operatorname{sSb}\!(H)$
be the structured subgraph induced by all of the remaining vertices. Suppose G is another acyclic directed graph. If
 $\varphi \colon H \to G$
is a graphical map and
 $\hat\varphi(H) \in \operatorname{sSb}\!(G)$
, then
 $\hat\varphi({\unicode{x2606}}_u)$
and
 $\hat\varphi(J)$
are structured subgraphs as well.
An almost isolated vertex in a graph with two or more vertices is one whose inputs (or outputs) are contained in the inputs (resp. outputs) of the graph so that deleting the vertex and all of its inputs (resp. outputs) leaves behind a connected graph.
Proof. Let
 be the active map in
 $\textbf{U}_{/\mathfrak{o}}$
from an acyclic directed graph with two vertices u, v which acts on vertices by
 $\alpha_1(v) = J \in \operatorname{sSb}\!(H)$
and
 $\alpha_1(u) = {\unicode{x2606}}_u \in \operatorname{sSb}\!(H)$
(that is,
 $\alpha$
is the graph complement of J from Definition 5·16). Using the active-inert factorisation of
 $\varphi$
, we have the following diagram

and by Lemma B14 we have
 $\psi_1(u) = K_u$
and
 $\psi_1(v) = K_v$
in
 $\operatorname{sSb}\!(\hat\varphi(H))$
. But
 $\psi_1(u) = \hat \beta([\iota_u])$
and
 $\psi_1(v) = \hat \beta([J \rightarrowtail H])$
, so since the composition of convex inclusions are again convex inclusions, we have
 $K_u, K_v \in \operatorname{sSb}\!(G)$
.
Lemma B16.
Suppose
 $\varphi = (\bar \varphi_0, \hat \varphi) \colon G \to G'$
is a map in
 $\textbf{U}_{/\mathfrak{o}}$
, with G and G′ acyclic. The restriction

exists if and only if
 $\hat \varphi([id_G]) \in \operatorname{sSb}\!(G')$
.
Proof. Since
 $G \in \operatorname{sSb}\!(G)$
, we see that the condition is necessary.
Now suppose
 $\hat \varphi (G)$
is in
 $\operatorname{sSb}\!(G')$
. Let
 $K\in \operatorname{sSb}\!(G)$
. If K is an edge, then
 $\hat \varphi(K)$
is an edge as well, hence a structured subgraph. We thus assume that K is has a vertex. We also assume that K has strictly fewer vertices than G, otherwise
 $K = G$
gets sent to a structured subgraph.
Using the characterisation of structured subgraph from [
Reference Hackney, Robertson and Yau29
, definition 6·32], the inclusion
 $K \rightarrowtail G$
admits a presentation as a composition of outer coface maps
 \begin{align*} K = K_0 \rightarrowtail K_1 \rightarrowtail \cdots \rightarrowtail K_m = G, \end{align*}
where
 $m\geq 0$
is the number of elements of
 $V_G \setminus V_K$
. This means (see [
Reference Hackney, Robertson and Yau29
, definition 2·60 and section 6·1·2]) that
 $K_{i+1}$
has an almost isolated vertex
 $v_i$
and
 $K_i\in \operatorname{sSb}\!(K_{i+1})$
is induced by all of the remaining vertices. If
 $\hat \varphi(K_{i+1})$
is in
 $\operatorname{sSb}\!(G')$
, then
 $\hat \varphi(K_i)$
is in
 $\operatorname{sSb}\!(G')$
by Lemma B15. But we knew
 $\hat \varphi(K_m) = \hat \varphi(G) \in \operatorname{sSb}\!(G')$
, and we conclude that
 $\hat \varphi(K) = \hat\varphi(K_0)$
is in
 $\operatorname{sSb}\!(G')$
.
Proposition B17.
Suppose
 $\varphi = (\bar \varphi_0, \hat \varphi) \colon G \to G'$
is a map in
 $\textbf{U}_{/\mathfrak{o}}$
, with G and G′ acyclic. If
 $\hat \varphi (G) \in \operatorname{sSb}\!(G')$
, then the restriction
 $(\bar\varphi_0, \check \varphi)$
from Lemma B16 is a properadic graphical map.
Proof. By Lemma B16 we know the restriction exists. We verify the two conditions from Definition B9. Condition (1) follows from Proposition 5·10(iv').
Suppose H and K are structured subgraphs of G so that
 $H \cup K \in \operatorname{sSb}\!(G)$
. Then
 $\check \varphi(H\cup K) \in \operatorname{sSb}\!(G')$
is a union of
 $\check \varphi(H)$
and
 $\check \varphi(K)$
, so
 \begin{align*} \check \varphi(H\cup K) = \check\varphi(H) \cup \check\varphi(K)\end{align*}
by Lemma B8. Thus
 $(\bar\varphi_0, \check \varphi)$
satisfies condition (2), hence is a properadic graphical map.
Theorem B18.
The properadic graphical category
 $\textbf{G}$
may be identified with the subcategory of
 $\textbf{U}_{/\mathfrak{o}}$
with:
-
(1) objects the acyclic directed graphs; and
-
(2) morphisms those
$\varphi \colon G \to G'$
so that
$\hat \varphi (G) \in \operatorname{sSb}\!(G')$
.


Proof. First observe that (2) is closed under composition:
 $\widehat{\psi\varphi}(G) = \hat \psi(\hat \varphi (G))$
is a structured subgraph by applying Lemma B16 to
 $\psi$
. We write
 $\textbf{M} \subseteq \textbf{U}_{/\mathfrak{o}}$
for the indicated subcategory.
By Proposition B17 there is a function
 $f_{G,G^{\prime}} \colon \textbf{M}(G,G') \to \textbf{G}(G,G')$
given by restriction. Since composition in each of
 $\textbf{M}$
and
 $\textbf{G}$
is given by composition of pairs of functions, this constitutes a functor
 $\textbf{M} \to \textbf{G}$
.
We also have a function
 \begin{equation}\begin{aligned}\textbf{G}(G,G') &\longrightarrow \textbf{U}_{/\mathfrak{o}}(G,G') \\[5pt] (\bar \varphi_0, \check \varphi) & \longmapsto (\varphi_0, \varphi_1) \sim (\bar \varphi_0, \hat \varphi)\end{aligned}\end{equation}
from Proposition B10 (using Proposition 5·10). We have isomorphisms

so that
 $\operatorname{in}\! (\hat \varphi (G)) = \operatorname{in}\! (\check \varphi (G))$
and
 $\operatorname{out}\! (\hat \varphi (G)) = \operatorname{out}\! (\check \varphi (G))$
as subsets of
 $E_{G^{\prime}}$
. To see that
 $\hat \varphi(G) = \check \varphi(G)$
in
 $\operatorname{Emb}\!(G')$
, it suffices by Lemma 2·15 to check that
 $\hat \varphi(G)$
is an edge if and only if
 $\check \varphi(G)$
is an edge; but these both occur if and only if
 $\varphi_1(v)$
is an edge for every v. Thus
 $\hat \varphi(G) = \check \varphi(G) \in \operatorname{sSb}\!(G')$
, and we conclude that the function (B1) factors through
 $d_{G,G^{\prime}} \colon \textbf{G}(G,G') \to \textbf{M}(G,G')$
.
Since maps in
 $\textbf{G}$
are uniquely determined by their actions on edge sets (Proposition B11) and these are preserved by f and d, we immediately have fd is the identity on
 $\textbf{G}(G,G')$
. On the other hand, if
 $df\varphi = \psi$
then
 $\psi_1$
is given by the left-bottom composite and
 $\varphi_1$
is given by the right-top composite in the commutative diagram

hence
 $\varphi_1 = \psi_1$
. Thus df is the identity on
 $\textbf{M}(G,G')$
, and we conclude that
 $\textbf{G}$
is isomorphic to
 $\textbf{M}$
.
Corollary B19.
The functor
 $\textbf{G}_{\textrm{act}} \to \textbf{U}_{/\mathfrak{o}}^{\textrm{act}}$
is fully faithful.
Proof. If G is an acyclic directed graph, then the inclusion
 $\operatorname{sSb}\!(G) \to \operatorname{Emb}\!(G)$
takes the unique maximal element G to the unique maximal element
 $[id_G]$
. Since active maps in both categories are those maps preserving the top element ([
Reference Chu and Hackney11
, definition 2·2·17] and Remark 4·16), the functor
 $\textbf{G} \to \textbf{U}_{/\mathfrak{o}}$
restricts. We already know that this functor is faithful.
If
 is an active map in
 $\textbf{U}_{/\mathfrak{o}}$
, then
 $\hat \varphi([id_G]) = [id_{G^{\prime}}] \in \operatorname{sSb}\!(G')$
, hence by Theorem B18 we know
 $\varphi$
is a map in
 $\textbf{G}$
. It is a map in
 $\textbf{G}_{\textrm{act}}$
because it takes
 $G\in \operatorname{sSb}\!(G)$
to
 $G'\in \operatorname{sSb}\!(G')$
.
Remark B20. Given a graphical category, we expect the subcategory of active maps to be closely related to a corresponding operadic category [ Reference Batanin and Markl4 ] (see [ Reference Berger9 , proposition 3·2]). If an operadic category for properads exists, the previous corollary suggests that it should simply be a full subcategory of the operadic category for wheeled properads from [ Reference Batanin and Markl5, Reference Batanin, Markl and Obradović6 ].
Recall that there is a full subcategory
 $\textbf{G}_{\textrm{sc}} \subset \textbf{G}$
(equivalent to the category called
 $\boldsymbol{\Theta}$
in [
Reference Hackney, Robertson and Yau29
, section 6·3·5]) whose objects are trees when considered as undirected graphs, that is, those graphs mapping to objects in the subcategory
 $\textbf{U}_{0} \subset \textbf{U}$
from Definition A1. For such a directed tree T, every embedding with codomain T is a convex inclusion. In particular, we have
 $\operatorname{sSb}\!(T) = \operatorname{Emb}\!(T)$
is the set of subtrees of T in the sense of Definition A4 (forgetting direction).
Corollary B21.
The induced functor
 $\textbf{G}_{\textrm{sc}} \to (\textbf{U}_{0})_{/\mathfrak{o}}$
is an equivalence.
Proof. If S and T are directed trees, then since
 $\operatorname{sSb}\!(T) = \operatorname{Emb}\!(T)$
, every map in
 $\textbf{U}_{/\mathfrak{o}}(S,T)$
satisfies condition (2) of Theorem B18. Hence
 \begin{align*}\textbf{G}_{\textrm{sc}}(S,T) = \textbf{G}(S,T) \to \textbf{U}_{/\mathfrak{o}}(S,T) = (\textbf{U}_{0})_{/\mathfrak{o}}(S,T)\end{align*}
is a bijection.
We can use this corollary to establish the following fact about undirected trees.
Proposition B22.
Theorem A7(v)(a) is redundant. That is, suppose G and G′ are undirected trees and
 $\varphi = (\varphi_0,\hat \varphi)$
is a pair consisting of an involutive function
 $\varphi_0 \colon A_G \to A_{G^{\prime}}$
and a function
 $\hat \varphi \colon \operatorname{Emb}\!(G) \to \operatorname{Emb}\!(G')$
. Then
 $\varphi$
is a new graph map (that is, a map in
 $\textbf{U}_{0}$
) if and only if it satisfies the following conditions:


Proof. We only need to prove the reverse implication. Suppose that
 $(\varphi_0, \hat \varphi) \colon G \to G'$
satisfies (iv) and (v) just above. Choose an arbitrary element
 $y \in \mathfrak{o}_{G^{\prime}}$
(where
 $\mathfrak{o}$
is the orientation presheaf from Definition 5·3), and define the element
 $x\in \mathfrak{o}_G$
by
 $x_a := y_{\varphi_0(a)}$
. Define, as usual,
 $\bar \varphi_0 \colon E_G \to E_{G^{\prime}}$
to be the map obtained from
 $\varphi_0$
by passing to
 $\dagger$
-orbits. We claim that
 \begin{align*} (\bar \varphi_0, \hat \varphi) \colon (G,x) \longrightarrow (G',y)\end{align*}
is a map in
 $\textbf{G}$
, hence in
 $\textbf{G}_{\textrm{sc}}$
. Once this is established, we will be done, since
 $(\bar \varphi_0, \hat \varphi)$
maps to
 $(\varphi_0, \hat \varphi) \colon (G,x) \to (G',y)$
under the equivalence
 $\textbf{G}_{\textrm{sc}} \to (\textbf{U}_{0})_{/\mathfrak{o}}$
from Corollary B21, hence
 $(\varphi_0, \hat \varphi)$
must be a map in
 $\textbf{U}_{0}$
.
Using the chosen orientations, the commutative diagram from (iv) splits into the middle two squares of

using the conventions of Definition 5·7. Hence Definition B9(1) holds.
On the other hand, we have that subtrees of G, structured subgraphs of G, and embeddings with codomain G all coincide. Further, the union of two subtrees S and T in the sense of Remark A6 is the same as the union of structured subgraphs in the sense of Remark B7, and this union is a structured subgraph if and only if S and T overlap. Thus (iv) implies Definition B9(2), and we conclude that
 $\varphi$
is a morphism in
 $\textbf{G}_{\textrm{sc}}$
, as desired.
Remark B23. It would be interesting to know whether or not the corresponding condition (2a) about intersections from [ Reference Hackney, Robertson and Yau32 , definition 1·12] is superfluous.
Appendix C. Nodeless loops and the extended graphical category
Whenever we talk about the graphical category
 $\textbf{U}$
or the oriented graphical category
 $\textbf{U}_{/\mathfrak{o}}$
, we would like to include the nodeless loop in our category. This is a graph without any vertices whose geometric realisation is a circle. We hope for this graph to show up, as it is used to represent the self-gluing of an identity element in a modular operad or a wheeled properad. (Note, however, that Raynor showed in [
Reference Raynor51
, section 7] that it is possible to give a monadic definition of these objects which does not require the nodeless loop to be regarded as a graph.) The reason we have mostly avoided the issue up until now is that Definitions 2·1 and 5·1 do not include nodeless loops, and in alternative combinatorial models for graphs (such as those found in [
Reference Batanin and Berger7, Reference Yau and Johnson61
]) the notion of ‘étale map,’ and hence ‘embedding,’ is not a first-class concept. One can modify the earlier definitions of graph to handle nodeless loops, but they become a good deal less elegant and not as easy to work with, which is why we did not do so from the start. Thus we are in the unfortunate state of affairs where there is no completely suitable combinatorial definition of graph with loose ends for our purposes.
Nevertheless, in this section we treat the extended graphical category
 $\widetilde{\textbf{U}}$
and show that Definition 4·2 also describes maps in this category, whereas in [
Reference Hackney, Robertson and Yau33
] we did not have a uniform definition for
 $\textbf{U}$
and
 $\widetilde{\textbf{U}}$
(compare Definition 2·9 and Definition C4). We emphasize that we are not out to describe a different operadic structure here: the nerve theorem of [
Reference Hackney, Robertson and Yau34
] holds equally well whether we have the nodeless loop or not, so
 $\textbf{U}$
and
 $\widetilde{\textbf{U}}$
both describe modular operads (though perhaps they do not describe the same notion of
 $\infty$
-modular operads).
In definition 4·1 of [
Reference Hackney, Robertson and Yau33
], the following refinement of the notion of graph from Definition 2·1 was presented that included explicit boundary data; that is, instead of having
 $\eth(G) = A_G \setminus D_G$
, it should merely be a subset satisfying certain properties.
Definition C1 (Extension of undirected graphs). A graph G consists of the data from Definition 2·1 together with a subset
 $\eth(G) \subseteq A_G$
satisfying:
-
(i)
$D_G^\dagger \setminus D_G \subseteq \eth(G) \subseteq A_G \setminus D_G$
; and -
(ii)
$\eth(G) \setminus D_G^\dagger$
is a
$\dagger$
-closed subset of
$A_G$
.


This allows one to encode graphs that have nodeless loops as connected components, but only adds (up to isomorphism) a single new connected graph:
Example C2. [
Reference Hackney, Robertson and Yau33
, definition 4·2]. A graph K is a nodeless loop if it has two arcs, an empty vertex set, and an empty boundary
 $\eth(K) = \varnothing$
. Such a graph K has exactly one internal edge, and K is not isomorphic to
 ${\updownarrow}$
.
Rather than repeat the general extended definition of embedding from Definition 4·6 of [ Reference Hackney, Robertson and Yau33 ], we will simply import the properties of nodeless loops that we need:
Proposition C3. Suppose K is a nodeless loop.
-
(1) If
$f \colon K \rightarrowtail G$
is an embedding, then f is an isomorphism (in particular, G is a nodeless loop as well).
-
(2) If
$h\colon H \rightarrowtail K$
is an embedding, then H is either isomorphic to the edge
${\updownarrow}$
or H is a nodeless loop.
-
(3) The set
$\operatorname{Emb}\!(K)$
consists of exactly two elements,
$[{\updownarrow}] < [id_K]$
, and the boundaries of these are
$\eth([{\updownarrow}]) = A_K$
and
$\eth([id_K]) = \varnothing$
.


We now recall the extension, from definition 4·7 of [ Reference Hackney, Robertson and Yau33 ], to Definition 2·9 to include the nodeless loops.
Definition C4 (Extended graphical category). Let G and G
′ be connected (undirected) graphs, including the possibility that one or both is a nodeless loop. A graphical map
 $\varphi \colon G \to G'$
is a pair
 $(\varphi_0, \varphi_1)$
consisting of an involutive function
 $\varphi_0 \colon A_G \to A_{G^{\prime}}$
and a function
 $\varphi_1 \colon V_G \to \operatorname{Emb}\!(G')$
, so that (i) and (ii) of Definition 2·9 hold, as well as
-
(iii') If the boundary of G is empty and
$\varphi_1(v)$
is an edge for every v, then G
′ is a nodeless loop.

These maps assemble into the extended graphical category, denoted
 $\widetilde{\textbf{U}}$
.
Remark C5 (Maps involving nodeless loops). There are few maps in
 $\widetilde{\textbf{U}}$
involving a nodeless loop K. Indeed, there is a non-trivial automorphism
 $K \to K$
which interchanges the two arcs, and any map
 $K \to G$
with domain a nodeless loop is an isomorphism between nodeless loops. There are more maps with codomain K. If G has a single vertex and no arcs (that is, G is isomorphic to
 ${\unicode{x2606}}_0$
), then there is a unique map
 $G \to K$
, and it sends the vertex to
 $[id_K] \in \operatorname{Emb}\!(K)$
. If all vertices of G have valence two, then there are exactly two maps
 $\varphi \colon G \to K$
– Definition 2·9(ii) forces
 $\varphi_1(v) = [{\updownarrow}]$
for each vertex v, and also shows that
 $nb(v) \hookrightarrow A_G \to A_K$
is a bijection of sets. As
 $\varphi_0$
is an involutive function,
 $A_G\to A_K$
is determined by the choice of where to send a single arc. There are no other maps with codomain K, see [
Reference Hackney, Robertson and Yau33
, remark 4·8].
When K is a nodeless loop, the notion of a union from Definition 3·1 and the notion of vertex disjoint from Definition 4·1 extend immediately to
 $\operatorname{Emb}\!(K)$
. Thus the new graph maps from Definition 4·2 still make sense when one of G or G
′ is a nodeless loop.
Theorem C6.
If G and G′ are connected graphs (including the possibility of a nodeless loop), then new graph maps
 $\varphi \colon G \to G'$
from Definition 4·2 are in bijection with the maps
 $G \to G'$
in the extended graphical category. This identifies the category of graphs (including the nodeless loops) and new graph maps with the extended graphical category.
Proof. In light of Theorem 4·15, we need only consider maps involving a nodeless loop K, and to establish the bijections it is enough to enumerate such maps. We then must show that any compositions
 $\varphi \circ \psi$
with a nodeless loop appearing as a domain or codomain of
 $\varphi$
or
 $\psi$
behave the same on both sides.
Suppose
 $\varphi \colon K \to G'$
is a new graphical map with K a nodeless loop. By Definition 4·2(iv),
 $\hat \varphi ([id_K])$
has empty boundary, so by Lemma 2·16 we have that the boundary of G
′ is empty and
 $\hat \varphi([id_K]) = [id_{G^{\prime}}]$
. On the other hand,
 $[id_K]$
is a union of
 $[{\updownarrow}]$
and
 $[{\updownarrow}]$
, so by conditions (i) and (ii) of Definition 4·2 we have
 $[id_{G^{\prime}}]$
is the union of edges, hence G
′ does not have any vertices. The only connected graphs with no vertices and an empty boundary are the nodeless loops.
Now that we’ve established G
′ is a nodeless loop and
 $\hat \varphi$
is an isomorphism, we conclude that the only data in the new graph map is the involutive function
 $\varphi_0 \colon A_K \to A_{G^{\prime}}$
, and there are exactly two such maps. By Remark C5 we have established a bijection between new graph maps and extended graphical maps from K to G
′.
Now suppose
 $G \to K$
is a new graph map. As the boundaries of elements of
 $\operatorname{Emb}\!(K)$
have cardinality zero and two, Definition 4·2(iv) implies that any vertices of G must have valence zero or two. In the first case, there is a unique map
 $G \to K$
. Indeed, if G has a vertex of valence zero, then it is isomorphic to
 ${\unicode{x2606}}_0$
. The set
 $\operatorname{Emb}\!({\unicode{x2606}}_0) \cong \operatorname{Emb}\!(G)$
is a singleton and preservation of boundary means that
 $\hat \varphi[id_G]$
must be
 $[id_K]$
.
If every vertex of G has valence two, then preservation of boundary implies that
 $nb(v) \to A_K$
is a bijection for every
 $v \in V_G$
, so the map
 $\varphi_0 \colon A_G \to A_K$
is determined by where it sends any individual arc (as in Remark C5). There is a unique function
 $\hat \varphi \colon \operatorname{Emb}\!(G) \to \operatorname{Emb}\!(K)$
satisfying condition (iv) of Definition 4·2, namely
 \begin{align*} \hat \varphi ([h]) = \begin{cases} [{\updownarrow}] & \text{if } \eth([h]) \neq \varnothing \\[5pt] [id_K] & \text{if } \eth([h]) = \varnothing. \end{cases}\end{align*}
Thus there are precisely two maps
 $G \to K$
in this second case.
By Remark C5 we have established the desired bijections for maps having the nodeless loop as its domain or codomain. It remains to show that compositions involving such a map behave the same whether considered as new graph maps or maps in the extended graphical category. But all maps involving the nodeless loop are completely determined by
 $\varphi_0$
, and the correspondence does not change the arc map.
C·1. The extended oriented graphical category
We now return to the oriented graphical category from Section 5. The original version of the wheeled properadic graphical category from [ Reference Hackney, Robertson and Yau29 ] included a (directed) nodeless loop. To cut down on enumerating multiple special cases, and in order to use the efficient Definition 5·1, we previously avoided the nodeless loop. We now add it back in.
The following is an extension of Definition 5·1, and is the directed version (and a simple translation using Construction 5·4 and Remark 5·5) of Definition C1.
Definition C7 (Extension of directed graphs). A directed graph consists of a diagram of finite sets
 \begin{align*} E_{G} \hookleftarrow I_{G} \rightarrow V_{G} \leftarrow O_{G} \hookrightarrow E_{G} \end{align*}
along with a pair of subsets
 $\operatorname{in}\!(G)$
and
 $\operatorname{out}\!(G)$
of
 $E_G$
so that:
-
(i)
$I_G \setminus O_G \subseteq \operatorname{in}\!(G) \subseteq E_G \setminus O_G$
; -
(ii)
$O_G \setminus I_G \subseteq \operatorname{out}\!(G) \subseteq E_G \setminus I_G$
; and -
(iii)
$\operatorname{in}\!(G) \setminus I_G = \operatorname{out}\!(G) \setminus O_G$
.


Notice that the graphs from Definition 5·1 are graphs in this sense. Indeed, if
 $\operatorname{in}\!(G) = E_G \setminus O_G$
and
 $\operatorname{out}\!(G) = E_G \setminus I_G$
, then
 \begin{align*} \operatorname{in}\!(G) \setminus I_G = E_G \setminus (O_G \cup I_G) = \operatorname{out}\!(G) \setminus O_G.\end{align*}
Below, we will write
 $L_G\subseteq E_G$
for the complement of
 $\operatorname{in}\!(G) \cup \operatorname{out}\!(G) \cup I_G \cup O_G$
.
Remark C8. For a graph G, the following are equivalent:
 $L_G =\varnothing$
,
 $\operatorname{in}\!(G) = E_G\setminus O_G$
, and
 $\operatorname{out}\!(G) = E_G \setminus I_G$
. In particular, the graphs of Definition 5·1 are precisely those graphs with
 $L_G = \varnothing$
. We will indicate the equivalence of the first two, as the equivalence of the first and third is identical. If
 $\operatorname{in}\!(G) = E_G \setminus O_G$
then
 \begin{align*} E_G = \operatorname{in}\!(G) \cup O_G \subseteq \operatorname{in}\!(G) \cup \operatorname{out}\!(G) \cup I_G \cup O_G = E_G \setminus L_G\end{align*}
and we conclude that
 $L_G$
is empty. On the other hand, suppose that
 $L_G = \varnothing$
. Then we have
 \begin{align*} E_G \setminus O_G = (\!\operatorname{in}\!(G) \cup \operatorname{out}\!(G) \cup I_G) \setminus O_G, \end{align*}
but
 $\operatorname{out}\!(G) \setminus O_G = \operatorname{in}\!(G) \setminus I_G \subseteq \operatorname{in}\!(G)$
and
 $I_G \setminus O_G \subseteq \operatorname{in}\!(G)$
by assumption, hence
 $E_G \setminus O_G \subseteq \operatorname{in}\!(G) \subseteq E_G \setminus O_G$
.
This more expansive definition of graph adds only a single new connected graph.
Example C9. The directed nodeless loop is the directed graph with
 $E_G = \ast$
and
 \begin{align*} I_G = V_G = O_G = \operatorname{in}\!(G) = \operatorname{out}\!(G) = \varnothing.\end{align*}
The following is an extension of Definition 5·2, and is the directed analogue of definition 4·6 of [ Reference Hackney, Robertson and Yau33 ].
Definition C10 (Embeddings). Suppose that G and H are directed graphs in the sense of Definition C7. A p-map from G to H is a natural transformation of underlying functors
 $\mathscr{G} \to \textbf{FinSet}$
so that:
-
(1) the two squares
are pullbacks; and
-
(2) if
$L_G \subseteq E_G$
is the complement of
$\operatorname{in}\!(G) \cup \operatorname{out}\!(G) \cup I_G \cup O_G$
, then
$L_G$
maps into
$L_H$
.


A p-map between connected graphs is an embedding just when
 $V_G \to V_H$
is injective.
Remark C11 (Terminology). Notice that if
 $L_G = \varnothing = L_H$
(see Remark C8), then a p-map is the same thing as an étale map from Definition 5·2. Further, the undirected analogue of p-map was called étale in [
Reference Hackney, Robertson and Yau33
, definition 4·6], but we are deliberately avoiding that terminology here. This is because a p-map (or an étale map from [
Reference Hackney, Robertson and Yau33
]) does not have much to do with either the geometric or algebraic situations. From the geometric perspective, we would expect étale maps to correspond to deformation classes of oriented local homeomorphisms of the associated topological graphs (see Remark 2·4), which implies that the nodeless loop should have a self-étale map of degree n for each
 $n\in \mathbb{N}$
, corresponding to the degree n map of the circle
 $S^1$
. Algebraically, elements of the free wheeled properad generated by H will be represented by natural transformations (with connected domain) satisfying only (1). We are unconvinced that the notion of p-map is widely useful on its own, except in the cases covered by Definition 5·2. On the other hand, the notion of embedding is still geometrically meaningful, as there is essentially only one injective local homeomorphism into the circle from either the open interval or the circle.
The orientation
 $\textbf{U}$
-presheaf
 $\mathfrak{o}$
from Definition 5·3 can be extended in a natural way to a
 $\widetilde{\textbf{U}}$
-presheaf (also called
 $\mathfrak{o}$
). That is, if K is a nodeless loop with arc set
 $\{ a, a^\dagger \}$
, then
 \begin{align*} \mathfrak{o}_K = \big\{ (x_a, x_{a^\dagger}) \mid x_a \in \{+1,-1\}, x_{a^\dagger} = -x_a \big\} \subseteq \prod_{A_K} \{+1,-1\} \end{align*}
contains two elements.
Proposition C12. Isomorphism classes of directed graphs in the sense of Definition C7 are in bijective correspondence with isomorphism classes of:
-
(i) maps of
$\widetilde{\textbf{U}}$
-presheaves of the form
$\coprod_{i=1}^n G_i \to \mathfrak{o}$
(with each
$G_i$
a representable presheaf associated to an undirected connected graph); -
(ii) directed Yau–Johnson graphs [ Reference Yau and Johnson61 , definition 1·21]; and
-
(iii) directed Batanin–Berger graphs [ Reference Batanin and Berger7 , 13·4].


Proof. This combines versions of [ Reference Kock43 , 1·1·13] and Construction 5·4 for the more general class of graphs, and the equivalences proposition 15·6 and (a variation of) proposition 15·2 from [ Reference Batanin and Berger7 ].
Definition C13. The extended oriented graphical category, denoted
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
, is the category whose objects are morphisms
 $G \to \mathfrak{o}$
from a representable presheaf to the orientation presheaf.
Theorem C14.
The extended oriented graphical category
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
is equivalent to the wheeled properadic graphical category which includes the nodeless loop. Morphisms may be described exactly as in Proposition 5·10.
This version of the wheeled properadic graphical category was called
 $\mathcal{A}$
in [
Reference Hackney, Robertson and Yau31
, section 2]. Our strategy below is similar to that from Theorem C6, namely to enumerate all maps involving nodeless loops.
Proof. First, the characterisation of morphisms in the extended oriented graphical category follows just like in Proposition 5·10.
Let
 $\widetilde{\textbf{C}}$
denote the wheeled properadic category which includes nodeless loops from [
Reference Hackney, Robertson and Yau31
, section 2], and let
 $\textbf{C}$
be the full subcategory which excludes them (using the conventions of Remark 5·14; note that nodeless loops have a unique listing). By sending a nodeless loop K to the
 $E_K$
-colored wheeled properad having just an identity morphism and its contraction, we obtain the extension to the functor from Proposition 5·15 below left.

To prove existence of the dashed equivalence, it suffices to compare hom-sets. We already have everything we need in Remark C5. In
 $\widetilde{\textbf{U}}_{/\mathfrak{o}}$
there is a unique map between two nodeless loops, and no other maps with a nodeless loop as the domain. Likewise, if K is a nodeless loop then there is a map
 $G \to K$
if and only if every vertex of G has one input and one output or the unique vertex of G has valence zero. If there is a map
 $G\to K$
, it is unique.
On the other hand, in the second paragraph of page 220 of [
Reference Hackney, Robertson and Yau31
] it was observed that only isomorphisms in
 $\widetilde{\textbf{C}}$
can have a nodeless loop as their domain, and a nodeless loop possesses a single automorphism (the identity). If
 $f \colon G \to K$
is a map whose codomain is a nodeless loop, we can form the (essentially unique) Reedy factorisation guaranteed by [
Reference Hackney, Robertson and Yau31
, theorem 1·2].

By the characterisation of plus maps in proposition 3·3 of [
Reference Hackney, Robertson and Yau31
], every vertex of H maps to a subgraph which is not an edge. Thus either H has a single vertex of valence zero (that is,
 $H\cong {\unicode{x2606}}_0$
) mapping the vertex to K or H does not have any vertices. In the latter case, H is either an edge or a nodeless loop. In any of these situations, the map
 $f^+ \colon H \to K$
is unique.
We now show that
 $f^-$
is unique as well. For each of these three graphs H, if
 $f^- \colon G \to H$
is an isomorphism then by [
Reference Hackney, Robertson and Yau31
, lemma 3·9] it is the unique such. This finishes the case when
 $H\cong {\unicode{x2606}}_0$
, as the only maps with this graph as their codomain are isomorphisms. Now when H is an edge or a nodeless loop, there is at most one minus map
 $G \to H$
(that is, isomorphic to a composition of codegeneracy maps [
Reference Hackney, Robertson and Yau29
, definition 9·39]), which sends every vertex to the edge subgraph and preserves boundaries. Thus the map
 $f^-$
is unique, and hence if there is a map
 $G \to K$
it is unique as well. Further, by our analysis of
 $f^-$
, every vertex of G has either precisely one input and one output, or G has a unique vertex of valence zero.
We have now established (unique) bijections between the sets of maps
 $G\to K$
or
 $K\to G$
in both categories whenever K is a nodeless loop. Since the vertical inclusions in (C1) are both sieves, we conclude that we can extend the identity-on-objects equivalence
 $\textbf{U}_{/\mathfrak{o}} \simeq \textbf{C}$
to the dashed functor, which is again an identity-on-objects equivalence.
If F is a functor whose domain category has an orthogonal factorisation system, and d is any object of the codomain, then there is a canonical orthogonal factorisation system on
 $F\downarrow d$
(or
 $d\downarrow F$
), generalizing the usual fact that a factorisation system on a category induces one on any (co)slice. We thus obtain the following from theorem 4·9 of [
Reference Hackney, Robertson and Yau33
], which lifts the factorisation system from Proposition 2·12 to the extended graphical category. See also the related result [
Reference Hackney, Robertson and Yau29
, proposition 9·75].
Corollary C15. The wheeled properadic graphical category has an active-inert orthogonal factorisation system.
Acknowledgements
This work owes a tremendous amount to numerous conversations about related topics with friends, colleagues and collaborators over the years. Marcy Robertson, in particular, deserves special thanks for encouraging me to write this up and to pursue some of the avenues of inquiry within.



