Nomenclature
- R, P
revolute, prismatic joints
- U, S
universal, spherical joints
- DOF
degree of freedom
-
 $m_{p},\,B$
moving platform and base of parallel wrist
- o, O
original points of m p , B
-
$\{m\}$
coordinate system o-xyz of m p at o,
-
$\{B\}$
coordinate system O-XYZ of B at O,
-
$s(\boldsymbol{\zeta})$
skew-symmetric matrix of vector
$\zeta$
-
$\{i_{j}\}$
coordinate system attached on the jth finger
-
$w_{j}, {{y}_{j}}^{\!\prime}$
tip point, input velocity of the jth finger
-
$\boldsymbol{{V}}_{wj}$
output velocity of the jth finger at
${w_j}$
in
$\{B\}$
-
$\boldsymbol{{J}}_{wj}$
Jacobian matrix of the jth finger
-
${}^{tj}\boldsymbol{{R}}_{j}$
rotational matrix from
$\{t_j\}$
to
$\{B\}$
-
$\boldsymbol{{V}}_{pr}$
general input velocity of parallel wrist
-
$\boldsymbol{{A}}_{pr}$
general input acceleration of parallel wrist
-
$\boldsymbol{{V}}_{r}$
general input velocity of parallel wrist, finger
-
$\boldsymbol{{A}}_{r}$
input acceleration of parallel wrist, finger
-
$\boldsymbol{{V}}_{f}$
general input velocity of fingers
-
$\boldsymbol{{J}}, \boldsymbol{{H}}$
Jacobian, Hessian matrix of parallel wrist
-
${g}_{i}$
moving link in
$r_{i}(g{=}p,\, q,\, i{=}0,\, 1,\, 2,\, 3)$
-
$\boldsymbol{\omega}_{i}, \boldsymbol\varepsilon_{i}$
angular velocity acceleration of
$r_{i}$
-
$\boldsymbol{{v}}_{gi}, \boldsymbol{{a}}_{gi}$
translational velocity acceleration of
$g_{i}\text{ in }r_{i}$
-
$\boldsymbol{{V}}_{gi}, \boldsymbol{{A}}_{gi}$
general (velocity, acceleration) of
$g_{i}\text{ in }r_{i}$
-
$\boldsymbol{{J}}_{vgi}$
translational Jacobian matrices of
$g_{i}\text{ in }r_{i}$
-
$\boldsymbol{{J}}_{\omega gi}$
rotational Jacobian matrices of
$g_{i}\text{ in }r_{i}$
-
$\boldsymbol{{H}}_{vgi}$
translational Hessian matrices of
$g_{i}\text{ in }r_{i}$
-
$\boldsymbol{{H}}_{\omega gi}$
rotational Hessian matrices of
$g_{i}\text{ in }r_{i}$
-
$\boldsymbol{{J}}_{gi}, \boldsymbol{{H}}_{gi}$
general Jacobian, Hessian matrix of
$g_{i}\text{ in }r_{i}$


1. Introduction
It has been an interesting and challenging issue in the robot industry to design and develop various industrial grippers and the finger mechanisms [Reference Honarpardaz, Tarkian and Olvander1–Reference Li, Cheng and Sun4] to grab heavy objects and to measure grabbing forces. Comparing with the serial mechanism, a parallel mechanism has several advantages, such as the high rigidity, short kinematic chain, high kinematic precision, and large capability of load bearing [Reference Craig5, Reference Huang, Li and Ding6]. Therefore, parallel mechanisms have been applied in the parallel machine tools, worktables, and parallel legs [Reference Zhang7, Reference Pan and Gao8], and some three degrees of freedom (DOF) parallel mechanisms are synthesized [Reference Craig5, Reference Huang, Li and Ding6, Reference Kong and Gosselin9]. Currently, some significant advances have been made in sophisticated biomimetic robotics systems using parallel mechanisms and several dexterous multifingers [Reference Li, Cheng, Gao, Xia and Jiang3, Reference Li, Cheng and Sun4, Reference Ebrahim10]. In this aspect, Spencer et al. presented the design and experimental results for a 16-finger highly underactuated microspine gripper for application in the deep ocean [Reference Spencer, Rina, Andrew, Andrew, Eric and Aaron11]. Jin et al. designed a dexterous hand based on several parallel finger structures [Reference Jin, Fang and Zhang12]. Fang et al. synthesized some parallel dexterous hands with a parallel finger structure based on Lie group [Reference Jin, Fang and Zhang13]. He et al. designed a finger mechanism with a redundant serial-parallel hybrid topology [Reference He, Li and Sun14]. Zheng et al. proposed a 12-section cable-driven hyper redundant manipulator with a puller follower controller [Reference Zheng, Wu and Chen15]. Li et al. developed a two-finger dexterous bionic hand with six DOFs [Reference Li, Hou and Mao16]. Isaksson et al. designed a 5-DOF redundant platform in order to transform the redundant platform motion into the motion of a grasper [Reference Isaksson, Gosselin and Marlow17]. Geng et al. presented a 3-DOF parallel micro-gripper and analyzed its kinematics [Reference Geng, Mills and Yao18]. However, the existing grippers formed by cable-driven redundant manipulator may have a less capability for grabbing the heavy object since a cable-driven finger has a lower load bearing capability.
The gripper formed by the links, gears, and cams may have both quite complex structure and large volume. In other hand, some existing 3-DOF parallel mechanisms may include some structure decoupling constraints which are sensitive to the manufacturing errors, so that their kinematic precision may be decreased and their manufacturing becomes difficult [Reference Han, Kim, Kim and Fran19]. The workspace of some existing 3-DOF parallel mechanisms may be small, so that the dexterity of the gripper formed by them is reduced. Hence, it has been a significant issue to develop a gripper using a 3-DOF parallel mechanism which is not sensitive to the manufacturing errors and has a high rigidity and a large workspace in order to grab heavy objects in large workspace and to measure grabbing force.
The main motivation of this paper is to develop a novel couple-constrained parallel wrist with three measuring force flexible fingers in order to increase the rigidity, the kinematic precision, and the capability of grabbing heavy object, and to measure grabbing load and to reduce impact grabbing force when the finger contacts with an object. The developed couple-constrained parallel wrist with three measuring force flexible fingers has the following merits:
-
1. Its parallel wrist contains a planar couple-constrained actuation mechanism P a and a SP (spherical joint-prismatic joint) center passive constrained limb r 0. Its kinematic precision and rigidity are increased by P a and r 0. Using r 0, the structure coupling constraints of the parallel wrist can be transformed into the structure decoupling constraints which are not sensitive to the manufacturing errors [Reference Zhang7]. Thus, both the kinematic precision and the rigidity of the parallel wrist can be increased. In addition, the manufacturing of the parallel wrist becomes easy.
-
2. The number of the links in the parallel wrist is reduced, and both the capability of load-bearing and the workspace are increased by P a since each of revolute joints in P a has larger capability of load-bearing and larger rotational angle than that of spherical or universal joint.
-
3. It can be used to grab heavy objects with various shapes. The contacting force between a fingertip and the grabbed object can be solved by measuring the force of the finger sensor.
-
4. A large grabbed impact can be reduced greatly by a pre-pressured spring installed in each finger.
However, the kinematics/dynamics models of the developed couple-constrained parallel wrist with three flexible finger have not been established; the grabbed forces have not been measured and the grabbing performances have not been discovered and analyzed yet. For this reason, the kinematics/dynamics and grabbing capability of the developed couple-constrained parallel wrist with three flexible finger are studied in this paper. Several contributions are conducted as follows:
-
1. Develop a novel prototype of a couple-constrained parallel wrist with three flexible fingers.
-
2. Derive Jacobian and Hessian matrices of the moving links such as the moving platform, the piston rods, the cylinder rods in four different limbs, and the connection rod in parallel wrist. Establish the kinematics models for solving the general velocity and acceleration of the moving links in order to establish dynamics model.
-
3. Establish a dynamics model for solving the dynamic actuation forces, the dynamic constrained forces and torque of the developed gripper. Verify the theoretical solutions by its simulation mechanism. Construct a workspace of the couple-constrained parallel wrist with three flexible fingers.
2. Kinematics of couple-constrained parallel wrist with three measuring force flexible finger
2.1 Structure performance analysis of prototype
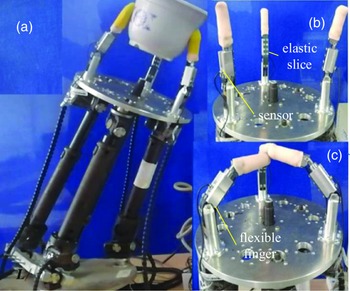
A prototype of the couple-constrained parallel wrist with three measuring force flexible finger is developed in Yanshan University, see Fig. 1.
Prototype of couple-constrained parallel wrist with three flexible fingers (a) The open and closed poses of three fingers (b), (c).

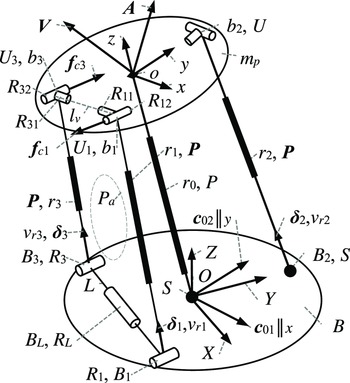
The kinematics model of the couple-constrained parallel wrist with the coordinate system and the couple-constrained forces is shown in Fig. 2. Let (S, P , P, R, U) denote (the spherical, actuation prismatic, prismatic, revolute, and universal) joint. The couple-constrained parallel wrist includes a moving platform m p , a fixed base B, a SPU (spherical joint - actuation prismatic joint - universal joint) actuation limb r 2 with a linear actuator, a SP-type center passive constrained rod r 0, a planar couple-constrained actuation mechanism P a , and three flexible fingers installed with sensors and springs. Here, P a is formed by 2 RPRR (revolute joint - actuation prismatic joint - revolute joint - revolute joint) linear actuation limbs r i (i = 1, 3), a connection rod L and m p . m p is a quaternary link with three connection points b i (i = 1, 2, 3) and a central connection point o. L is a ternary link with 2 connection joints at B i (i = 1, 3) and a center connection point B L . B is a ternary link with two connection points (B L , B 2) and a central connection point O.
Kinematics model of couple-constrained parallel wrist.

Each of r
i
(i = 1, 3) has a linear actuator. The lower ends of r
i
are connected with the two ends of L at points B
i
(i = 1, 3) by the revolute joints R
i
(i = 1, 3). The upper end of r
i
is connected with m
p
at b
i
using the universal joint U
i
formed by two crossed revolute joints R
i1 and R
i2. r
0 is formed by a piston rod r
p0 and a cylinder r
q0. r
p0 is perpendicular to m
p
, and the upper end of r
p0 is fixed onto m
p
at o. The lower end of r
p0 is coaxially connected with r
q0 by p joint. The lower end of r
q0 is connected with B at O by S joint. L is connected with B at B
L
by a revolute joint R
L
. The upper end of r
2 is connected with m
p
at b
2 by U joint. The lower end of r
2 is connected with B at B
2 by S joint. b
i
(i = 1, 2, 3) are uniformly located in the same circumference of m
p
. B
i
(i = 1, 3) and B
2 are located in the same circumference of B. Let (||,
 $\perp$
, |) be the parallel constraint, perpendicular constraint, and collinear constraint, respectively. Let l
v
be a line from b
1 to b
3. The geometric constraints {R
L
|L; L||X, R
i
 $\perp$
L (i = 1, 3); R
1||R
3||R
12||R
32; R
i
 $\perp$
r
i
; R
11|R
31; R
11
 $\perp$
R
12; R
31
 $\perp$
R
32; x||l
v
; z
 $\perp$
m; Z
 $\perp$
B} are satisfied. In this case, R
11 and R
31 are always kept in the same rotation. Based on a revised Grübler–Kutzbach equation [Reference Huang, Li and Ding6], the DOF of the couple-constrained parallel wrist is calculated as follows:
 \begin{align} M & =6(n_{0}-n-1)+\sum M_{i}+\varsigma -M_{0}\nonumber\\ & =6\times (\textrm{10}-12-1)+18+3=3 \end{align}
The number of the links is n 0 = 10 including one m p with the piston rod of r 0, one cylinder of r 0, 1 B, 1 L, 3 cylinders of r i (i = 1, 2, 3), and three piston rods of r i ; the number of the kinematic pairs is n = 12 including {R 1, R 3, R L , U 1, U 3, 2S, 1U, 4P}; the sum of local DoFs of the kinematic pairs is ΣM i = 18 since (R 1, R 3, R L , 4P) provide seven local DOFs, 2S provide six local DOFs, 1U provide two local DOFs, and {U 1, U 3} provide three local DOFs because R 11 and R 31 are with the same rotation; the redundant constraint is ς = 3 for P a ; and passive DOF is M 0 = 0.
DOF of the flexible finger is calculated as 1 in ref. [Reference Lu, Chang and Lu20].
2.2 Kinematics model of moving platform
The couple-constrained parallel wrist includes several moving links. Let {m} be a coordinate system o-xyz fixed on m
p
at o, {B} be a coordinate system O-XYZ fixed on B at O. Let {
r
i
,
 $\boldsymbol\delta$
i
(i = 1, 2, 3)} be the vector of the actuation limb r
i
and its unit vector, respectively,
e
i
be the vector from o to b
i
, {
m
b
i
,
b
i
(i = 1, 2, 3)} be the vector position of connection point b
i
on m
p
in {m} and {B}, respectively. Let {
B
i
(i = 1, 2, 3)} be the vector position of the connection point B
i
on B in {B}, (
o
, X
o
, Y
o
, Z
o
) be the vector position of point o on m
p
in {B} and its three components. Let (x
l
, x
m
, x
n
, y
l
, y
m
, y
n
, z
l
, z
m
, z
n
) be the nine orientation parameters of m
p
in {B}, (
 $\alpha, \beta, \gamma$
) be three Euler angles. Let e
i
= e (i = 1, 2, 3) be the distance from o to b
i
, E
i
be the distance from O to B
i
,
 $\varphi$
i
be the angle between x and the line from o to b
i
,
L
be the unit vector of L,
l
v
be the unit vector of l
v
,
 $\varphi$
be one of (
 $\alpha, \beta, \gamma, \varphi_i, \theta_6$
). Set
 $s_\varphi$
= sin
 $\varphi$
,
 $c_\varphi$
= cos
 $\varphi$
,
 $t_\varphi$
= tan
 $\varphi$
. Let
 $ _m^B{\boldsymbol{{R}}} $
be a rotation matrix from {m} to {B} in the order of XYX.
 $ \{ _m^B{\boldsymbol{{R}}}, {}^m{\boldsymbol{{b}}}_i, \boldsymbol{{b}}_i, \boldsymbol{{B}}_i (i=1,2,3)\} $
are represented as follows:
 \begin{equation} _{m}^{B}{\boldsymbol{{R}}}=\left(\begin{array}{c@{\quad}c@{\quad}c} x_{l}=c_{\beta } & y_{l}=s_{\beta }s_{\gamma } & z_{l}=s_{\beta }c_{\gamma }\\ x_{m}=s_{\alpha }s_{\beta } & y_{m}=c_{\alpha }c_{\gamma }-s_{\alpha }c_{\beta }s_{\gamma } & z_{m}=-c_{\alpha }s_{\gamma }-s_{\alpha }c_{\beta }c_{\gamma }\\ x_{n}=-c_{\alpha }s_{\beta } & y_{n}=s_{\alpha }c_{\gamma }+c_{\alpha }c_{\beta }s_{\gamma } & z_{n}=-s_{\alpha }s_{\gamma }+c_{\alpha }c_{\beta }c_{\gamma } \end{array}\right) \end{equation}
 \begin{equation} \begin{array}{l} ^{m}{\boldsymbol{{b}}}{_{i}^{}}=\left(\begin{array}{c} X_{bi}\\ Y_{bi}\\ Z_{bi} \end{array}\right)=e_{i}\left(\begin{array}{c} c_{\varphi i}\\ s_{\varphi i}\\ 0 \end{array}\right)\!,\boldsymbol{{B}}_{i}=\left(\begin{array}{c} X_{Bi}\\ Y_{Bi}\\ Z_{Bi} \end{array}\right)=E_{i}\left(\begin{array}{c} c_{\varphi i}\\ s_{\varphi i}\\ 0 \end{array}\right)\!, \\[16pt] \boldsymbol{{l}}_{v}=\boldsymbol{{x}}=\left(\begin{array}{c} c_{\beta }\\ s_{\alpha }s_{\beta }\\ -c_{\alpha }s_{\beta } \end{array}\right)\!, \ \boldsymbol{{L}}=\boldsymbol{{X}}=\left(\begin{array}{c} 1\\ 0\\ 0 \end{array}\right)\!, \begin{array}{c} \varphi _{1}=330^{\circ},\\ \varphi _{2}=90^{\circ},\\ \varphi _{3}=210^{\circ} \end{array} \end{array} \end{equation}
 \begin{equation} \boldsymbol{{o}}=\left(\begin{array}{c} X_{o}\\ Y_{o}\\ Z_{o} \end{array}\right)\!,\ \boldsymbol{{b}}_{i}= {}_{m}^{B}{\boldsymbol{{R}}}\, {}^{m}{\boldsymbol{{b}}}{_{i}^{}}+\boldsymbol{{o}}=\left(\begin{array}{c} e_{i}c_{\varphi i}x_{l}+e_{i}s_{\varphi i}y_{l}+X_{o}\\ e_{i}c_{\varphi i}x_{m}+e_{i}s_{\varphi i}y_{m}+Y_{o}\\ e_{i}c_{\varphi i}x_{n}+e_{i}s_{\varphi i}y_{n}+Z_{o} \end{array}\right) \end{equation}
The formulas for solving the inverse displacement r i (i = 1, 2, 3) are derived from Eqs. (2a), (2b), (2c) as follows:
 \begin{equation} \begin{array}{l} \left(\boldsymbol{{l}}_{v}\boldsymbol{{r}}_{1}\boldsymbol{{L}}\right)=0\rightarrow \left| \begin{array}{c@{\quad}c@{\quad}c} x_{l} & x_{m} & x_{n}\\ X_{b1}-X_{B1} & Y_{b1}-Y_{B1} & Z_{b1}-Z_{B1}\\ 1 & 0 & 0 \end{array}\right| =0\\[16pt] x_{m}\left(Z_{b1}-Z_{B1}\right)-x_{n}\left(Y_{b1}-Y_{B1}\right)=0\rightarrow \\[10pt] c_{\gamma }=\dfrac{E_{1}s_{\varphi 1}c_{\alpha }-s_{\alpha }Z_{o}-c_{\alpha }Y_{o}}{e_{1}s_{\varphi 1}} \end{array} \end{equation}
 \begin{equation} \begin{array}{l} \boldsymbol{{r}}_{i}=\boldsymbol{{b}}_{i}-\boldsymbol{{B}}_{i}=\left(\begin{array}{c} e_{i}c_{\varphi i}x_{l}+e_{i}s_{\varphi i}y_{l}+X_{o}-E_{i}c_{\varphi i}\\ e_{i}c_{\varphi i}x_{m}+e_{i}s_{\varphi i}y_{m}+Y_{o}-E_{i}s_{\varphi i}\\ e_{i}c_{\varphi i}x_{n}+e_{i}s_{\varphi i}y_{n}+Z_{o} \end{array}\right)\!, \\[16pt] r_{0}^{2}=X_{o}^{2}+Y_{o}^{2}+Z_{o}^{2}, \boldsymbol{\delta }_{i}=\dfrac{\boldsymbol{{r}}_{i}}{\big| \boldsymbol{{r}}_{i}\big| }, i=1,2,3 \end{array} \end{equation}
It is found from the structure performance in Fig. 2 that the parallel wrist includes two independent constrained forces
 $\,\boldsymbol{{f}}_{\!c0i}$
(i = 1, 2) and two couple-constrained forces
f
ci
(i = 1, 3).
f
c0i
(i = 1, 2) are exerted onto r
0 at O,
f
ci
are exerted onto m
p
at b
i
(i = 1, 3). Let ( f
c0i
,
c
i0) be the scalar and unit vectors of
f
c0i
. Since
f
c0i
(i = 1, 2) do not generate any power during the moving of r
0, (
f
c0i
 $\perp$
r
0,
f
c0i
|O) must be satisfied. Since there are (x
 $\perp$
r
0, y
 $\perp$
r
0), (
c
01 =
x
,
c
02 =
y
) are satisfied. Based on the principle of virtual power,
f
c0i
(i = 1, 2) and their constrained torques satisfy
 \begin{equation}\begin{array}{l} f_{c0i}\boldsymbol{{c}}_{0i} \cdot \boldsymbol{{v}}+ \left(f_{c0i}\boldsymbol{{c}}_{0i}\times \boldsymbol{{o}}\right) \cdot \boldsymbol{\omega }=0 \rightarrow \\[6pt] \left(\begin{array}{c@{\quad}c} \boldsymbol{{x}}^{T} & \left(\boldsymbol{{x}}\times \boldsymbol{{o}}\right)^{T} \end{array}\right)\boldsymbol{{V}}=0, \left(\begin{array}{c@{\quad}c} \boldsymbol{{y}}^{T} & \left(\boldsymbol{{y}}\times \boldsymbol{{o}}\right)^{T} \end{array}\right)\boldsymbol{{V}}=0 \end{array}\end{equation}
here, x , y, and o are the unit vectors of x, the unit vector of y and the vector of o in {B}, respectively.
Let (
 $f_{ci}$
,
c
i
) be the scalar and unit vectors of
f
ci
. Since
f
ci
(i = 1, 3) do not generate any power during the moving of m
p
, (
c
i
|R
i2 and
c
3 =
−c
1) must be satisfied. Let t
ci
(i = 1, 3) be the constrained torques exerted onto L. Let
L
be the unit vector of L. {(
f
ci
×
r
i
)·
L
= t
ci
, (i = 1, 3); t
c1=t
c3, t
ci
|L} are satisfied based on the balancing condition of the constrained torques. Therefore, there are
 \begin{equation} \left(\boldsymbol{{r}}_{1} \times f_{c1}\boldsymbol{{c}}_{1}+ \boldsymbol{{r}}_{3} \times f_{c3}\boldsymbol{{c}}_{3}\right) \cdot \boldsymbol{{L}}=\textrm{0} \rightarrow \end{equation}
 \begin{equation*} f_{c3}=- \frac{\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right) \cdot \boldsymbol{{L}}}{\left(\boldsymbol{{r}}_{3}\times \boldsymbol{{c}}_{3}\right) \cdot \boldsymbol{{L}}}f_{c1},\boldsymbol{{c}}_{1}=\boldsymbol{{x}}\times \boldsymbol{\delta }_{1},\boldsymbol{{c}}_{3}=- \boldsymbol{{c}}_{1} \end{equation*}
Since neither the couple-constrained forces
f
ci
(i = 1, 3) nor the couple-constrained torques
e
i
×
f
ci
generate power, (
f
c1||
f
c3,
c
i
 $\perp$
 $\boldsymbol\delta$
i
,
c
i
||
R
i
) are satisfied. It is known from the principle of virtual power that the couple-constrained wrench must satisfy
 \begin{equation} \begin{array}{l} \left(f_{c1}\boldsymbol{{c}}_{1}+f_{c3}\boldsymbol{{c}}_{3}\right) \cdot \boldsymbol{{v}}+\left(\boldsymbol{{e}}_{1}\times f_{c1}\boldsymbol{{c}}_{1}+\boldsymbol{{e}}_{3}\times f_{c3}\boldsymbol{{c}}_{3}\right) \cdot \boldsymbol{\omega }=0,\\[3pt] \boldsymbol{{e}}_{3}=\boldsymbol{{e}}_{1}- l_{v}\boldsymbol{{x}} \end{array} \end{equation}
Substitute Eq. (5) for Eq. (6), it leads to
 \begin{equation}\begin{array}{l} \left\{ \left[ \left(\boldsymbol{{r}}_{3}\times \boldsymbol{{c}}_{3}\right)\mathbf{\cdot }\boldsymbol{{L}}\right]\boldsymbol{{c}}_{1} - \left[\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right)\cdot\boldsymbol{{L}}\right]\boldsymbol{{c}}_{3}\right\}\cdot\boldsymbol{{v}}+\left\{\boldsymbol{{e}}_{1}\times \left[\left(\left(\boldsymbol{{r}}_{3}\times \boldsymbol{{c}}_{3}\right)\cdot\boldsymbol{{L}}\right)\cdot \boldsymbol{{c}}_{1}\right.\right.\\[6pt] \left.\left. - \left(\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right)\cdot\boldsymbol{{L}}\right)\cdot\boldsymbol{{c}}_{3}\right]+l_{v}\boldsymbol{{x}}\times\left(\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right)\cdot\boldsymbol{{L}}\right)\cdot \boldsymbol{{c}}_{3}\right\}\cdot\boldsymbol{\omega }=0 \end{array} \end{equation}
Eq. (7) can be simplified as below:
 \begin{equation} \boldsymbol{{c}}\cdot \boldsymbol{{v}}+\boldsymbol{\tau }\cdot \boldsymbol{\omega }=0,\left(\begin{array}{c@{\quad}c} \boldsymbol{{c}}^{T} & \boldsymbol{\tau }^{T} \end{array}\right)\boldsymbol{{V}}=0 \end{equation}
The items
c
and
 $\boldsymbol\tau$
in Eq. (8) are derived from Eq. (7) and
c
3 =
−c
1 as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{c}}=\left\{\left[\left(\boldsymbol{{r}}_{3}\times \boldsymbol{{c}}_{3}\right) \cdot \boldsymbol{{L}}\right]\boldsymbol{{c}}_{1}- \left[\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right) \cdot \boldsymbol{{L}}\right]\boldsymbol{{c}}_{3}\right\}/l_{v}\\[3pt] =\left\{- \left[\left(\boldsymbol{{r}}_{3}\times \boldsymbol{{c}}_{1}\right) \cdot \boldsymbol{{L}}\right]\boldsymbol{{c}}_{1}+ \left[\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right) \cdot \boldsymbol{{L}}\right]\boldsymbol{{c}}_{1}\right\}/l_{v}\\[3pt] =\left\{- \left[\left(\boldsymbol{{L}}\times \boldsymbol{{r}}_{3}\right) \cdot \boldsymbol{{c}}_{1}\right]\boldsymbol{{c}}_{1}+ \left[\left(\boldsymbol{{L}}\times \boldsymbol{{r}}_{1}\right) \cdot \boldsymbol{{c}}_{1}\right]\boldsymbol{{c}}_{1}\right\}/l_{v}\\[3pt] =\boldsymbol{{L}}\times \left(\boldsymbol{{r}}_{1}- \boldsymbol{{r}}_{3}\right)/l_{v}=\boldsymbol{{L}} \times \left(l_{v}\boldsymbol{{x}}- L\boldsymbol{{L}}\right)/l_{v}=\boldsymbol{{X}}\times \boldsymbol{{x}}, \end{array} \end{equation}
 \begin{equation} \begin{array}{l} \boldsymbol{\tau }=\boldsymbol{{e}}_{1}\times \left\{\left[\left(\boldsymbol{{r}}_{3}\times \boldsymbol{{c}}_{3}\right) \cdot \boldsymbol{{L}}\right]\boldsymbol{{c}}_{1}- \left[\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right) \cdot \boldsymbol{{L}}\right]\boldsymbol{{c}}_{3}\right\}/l_{v}\\[3pt]\qquad\! + l_{v}\boldsymbol{{x}}\times \left[\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right) \cdot \boldsymbol{{L}}\right]\boldsymbol{{c}}_{3}/l_{v}\\[3pt] =\boldsymbol{{e}}_{1}\times \boldsymbol{{c}}+\boldsymbol{{x}}\times \left[\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right) \cdot \boldsymbol{{L}}\right]\boldsymbol{{c}}_{3}\\[3pt] =\boldsymbol{{e}}_{1}\times \boldsymbol{{c}}- \boldsymbol{{x}}\times \left[\left(\boldsymbol{{L}}\times \boldsymbol{{r}}_{1}\right) \cdot \boldsymbol{{c}}_{1}\right]\boldsymbol{{c}}_{1}\\[3pt] =\boldsymbol{{e}}_{1} \times \boldsymbol{{c}}- \boldsymbol{{x}}\times \left(\boldsymbol{{L}} \times \boldsymbol{{r}}_{1}\right)=\boldsymbol{{e}}_{1} \times \boldsymbol{{c}}- \boldsymbol{{x}}\times \left(\boldsymbol{{X}} \times \boldsymbol{{r}}_{1}\right) \end{array} \end{equation}
Let {v ri , a ri (i = 1, 2, 3)} be the input (velocity, acceleration) of the parallel wrist along r i . The formula for solving v ri is represented as below:
 \begin{equation} v_{ri}=\left(\begin{array}{c@{\quad}c} \boldsymbol{\delta }_{i}^{T} & \left(\boldsymbol{{e}}_{i}\times \boldsymbol{\delta }_{i}\right)^{T} \end{array}\right)\boldsymbol{{V}} \end{equation}
Let ( V pr , A pr ) be the general input velocity, the acceleration of the couple-constrained parallel wrist. Let ( V , A ) be the general output velocity, the acceleration of m at o. Based on the formulas for solving the displacement and the couple constrained forces, the relations of ( V pr , V ) of the couple-constrained parallel wrist are derived from Eqs. (9a), (9b), (10) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{V}}_{pr}=\boldsymbol{{JV}},\ \boldsymbol{{V}}=\boldsymbol{{J}}^{-1}\boldsymbol{{V}}_{pr},\ \boldsymbol{{V}}^{T}=\boldsymbol{{V}}_{r}^{T}\left(\boldsymbol{{J}}^{-1}\right)^{T},\\[6pt] \boldsymbol{{V}}_{pr}=\left(\begin{array}{l} \begin{array}{l} v_{r1}\\[3pt] v_{r2}\\[3pt] v_{r3} \end{array}\\[3pt] \begin{array}{l} 0\\[3pt] 0\\[3pt] 0 \end{array} \end{array}\right)\!,\ \boldsymbol{{J}}=\left(\begin{array}{c@{\quad}c} \boldsymbol{\delta }_{1}^{T} & \left(\boldsymbol{{e}}_{1}\times \boldsymbol{\delta }_{1}\right)^{T}\\[3pt] \boldsymbol{\delta }_{2}^{T} & \left(\boldsymbol{{e}}_{2}\times \boldsymbol{\delta }_{2}\right)^{T}\\[3pt] \boldsymbol{\delta }_{3}^{T} & \left(\boldsymbol{{e}}_{3}\times \boldsymbol{\delta }_{3}\right)^{T}\\[3pt] \boldsymbol{{x}}^{T} & \left(\boldsymbol{{x}}\times \boldsymbol{{o}}\right)^{T}\\[3pt] \boldsymbol{{y}}^{T} & \left(\boldsymbol{{y}}\times \boldsymbol{{o}}\right)^{T}\\[3pt] \boldsymbol{{c}}^{T} & \boldsymbol{\tau }^{T} \end{array}\right) \end{array} \end{equation}
The relations of ( A pr , A ) of the couple-constrained parallel wrist are derived from Eqs. (11a) as follows:
 \begin{equation} \begin{array}{l}\boldsymbol{{A}}_{pr}=\boldsymbol{{JA}}+\boldsymbol{{J}}'\boldsymbol{{V}}=\boldsymbol{{JA}}+ \boldsymbol{{V}}^{T}\boldsymbol{{HV}},\ \boldsymbol{{J}}'=\boldsymbol{{V}}^{T}\boldsymbol{{H}},\\[6pt] \boldsymbol{{A}}_{pr}=\left( \begin{array}{l} a_{r1}\\[3pt] a_{r2}\\[3pt] a_{r3} \\[3pt] 0\\[3pt] 0\\[3pt] 0 \end{array} \right)\!,\ \boldsymbol{{J}}'=\left(\begin{array}{c@{\quad}c} \boldsymbol{\delta }_{1}^{\prime T} & \left(\boldsymbol{{e}}_{1}\times \boldsymbol{\delta }_{1}\right)^{\prime T}\\[3pt] \boldsymbol{\delta }_{2}^{\prime T} & \left(\boldsymbol{{e}}_{2}\times \boldsymbol{\delta }_{2}\right)^{\prime T}\\[3pt] \boldsymbol{\delta }_{3}^{\prime T} & \left(\boldsymbol{{e}}_{3}\times \boldsymbol{\delta }_{3}\right)^{\prime T}\\[3pt] \boldsymbol{{x}}^{\prime T} & \left(\boldsymbol{{x}}\times \boldsymbol{{o}}\right)^{\prime T}\\[3pt] \boldsymbol{{y}}^{\prime T} & \left(\boldsymbol{{y}}\times \boldsymbol{{o}}\right)^{\prime T}\\[3pt] \boldsymbol{{c}}^{\prime T} & \boldsymbol{\tau }^{\prime T} \end{array}\right)\!,\ \boldsymbol{{H}}=\left(\begin{array}{l} \boldsymbol{{h}}_{1}\\[3pt] \boldsymbol{{h}}_{2}\\[3pt] \boldsymbol{{h}}_{3} \\[3pt] \boldsymbol{{h}}_{4}\\[3pt] \boldsymbol{{h}}_{5}\\[3pt] \boldsymbol{{h}}_{6} \end{array}\right) \end{array} \end{equation}
here,
J
and
H
are the 6 × 6 Jacobian matrix and the six layers 6 × 6 Hessian matrix of the couple-constrained parallel wrist, respectively;
h
i
(i = 1, 2, 3) are the 6 × 6 sub-matrices of
H
corresponding to the actuation forces
 ${f}_{ai}$
along r
i
; (
h
4,
h
5) are the 6 × 6 sub-matrices of
H
corresponding to constrained forces (
f
c01,
f
c02), respectively;
h
6 is the 6 × 6 sub-matrix of
H
corresponding to
f
ci
(i = 1, 3).
In order to solve the sub-items of H in Eq. (11), several extended skew-symmetric matrices and relative formulas are derived and explained as follows.
Let
 ${\boldsymbol{\zeta }}$
and
 $\hat{\boldsymbol{\zeta }}=s(\boldsymbol{\zeta })$
be a vector and its skew-symmetric matrix, respectively. Let
C
be a three layers 3 × 3 constant matrix. Let
I
k
(k = 1, 2, 3) be the 3 × 3 sub-matrixes of
C
. The relative formulas are represented by [Reference Lu, Ye and Chang21].
The formulas for solving h i (i = 1, 2, 3) in Eq. (11b) are derived by [Reference Lu and Hu22]. The formulas for solving h 4 and h 5 in Eq. (11b) are derived as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{x}}'=\boldsymbol{\omega }\times \boldsymbol{{x}},\ \boldsymbol{{x}}'^{T}=\boldsymbol{\omega }^{T}\hat{\boldsymbol{{x}}}=\boldsymbol{{V}}^{T}\left(\begin{array}{l} \boldsymbol{0}\\ \hat{\boldsymbol{{x}}} \end{array}\right),\ (\boldsymbol{{x}}\times \boldsymbol{{o}})'^{T}=\boldsymbol{{V}}^{T}\left(\begin{array}{l} -\hat{\boldsymbol{{x}}}\\ \hat{\boldsymbol{{x}}}\hat{\boldsymbol{{o}}} \end{array}\right)\!, \\[10pt] \boldsymbol{{h}}_{4}=(\begin{array}{c@{\quad}c} \boldsymbol{{x}}'^{T} & (\boldsymbol{{x}}\times \boldsymbol{{o}})'^{T} \end{array})=\left(\begin{array}{c@{\quad}c} \boldsymbol{0} & -\hat{\boldsymbol{{x}}}\\ \hat{\boldsymbol{{x}}} & \hat{\boldsymbol{{x}}}\hat{\boldsymbol{{o}}} \end{array}\right),\ \boldsymbol{{h}}_{5}=\left(\begin{array}{c@{\quad}c} \boldsymbol{0} & -\hat{\boldsymbol{{y}}}\\ \hat{\boldsymbol{{y}}} & \hat{\boldsymbol{{y}}}\hat{\boldsymbol{{o}}} \end{array}\right) \end{array} \end{equation}
The formulas for solving h 6 in Eq. (11b) are derived as
 \begin{equation} \begin{array}{l} \boldsymbol{{c}}'=\left(\boldsymbol{{X}}\times \boldsymbol{{x}}\right)^\prime=\boldsymbol{{X}}\times \left(\boldsymbol{\omega }\times \boldsymbol{{x}}\right)=\left(\begin{array}{c@{\quad}c} \boldsymbol{0}_{3\times 3} & -\hat{\boldsymbol{{X}}}\hat{\boldsymbol{{x}}} \end{array}\right)\boldsymbol{{V}},\\ \boldsymbol{{c}}'=\left(\begin{array}{c@{\quad}c} \boldsymbol{{h}}_{c1} & \boldsymbol{{h}}_{c2} \end{array}\right)\boldsymbol{{V}},\boldsymbol{{h}}_{c1}=\boldsymbol{0}_{3\times 3},\boldsymbol{{h}}_{c2}=-\hat{\boldsymbol{{X}}}\hat{\boldsymbol{{x}}},\boldsymbol{{r}}'_{\!\!1}=\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{1} \end{array} \end{equation}
 \begin{equation} \begin{array}{l} \boldsymbol{\tau }'=\left(\boldsymbol{{e}}_{1}\times \boldsymbol{{c}}\right)^\prime-\left(\boldsymbol{{x}}\times \boldsymbol{{W}}\right)^\prime\\ \quad =\left(\hat{\boldsymbol{{c}}}\hat{\boldsymbol{{e}}}_{1}-\hat{\boldsymbol{{e}}}_{1}\hat{\boldsymbol{{X}}}\hat{\boldsymbol{{x}}}-\hat{\boldsymbol{{W}}}\hat{\boldsymbol{{x}}}+\hat{\boldsymbol{{x}}}\hat{\boldsymbol{{X}}}\hat{\boldsymbol{{e}}}_{1}\right)\boldsymbol{\omega }-\hat{\boldsymbol{{x}}}\hat{\boldsymbol{{X}}}\boldsymbol{{v}}=\left(\begin{array}{c@{\quad}c} \boldsymbol{{h}}_{\tau 1} & \boldsymbol{{h}}_{\tau 2} \end{array}\right)\boldsymbol{{V}} \end{array} \end{equation}
 \begin{equation} \begin{array}{l} \boldsymbol{{W}}=\boldsymbol{{X}}\times \boldsymbol{{r}}_{1},\ \boldsymbol{{h}}_{\tau 1}=-\hat{\boldsymbol{{x}}}\hat{\boldsymbol{{X}}},\\[6pt] \boldsymbol{{h}}_{\tau 2}=\hat{\boldsymbol{{c}}}\hat{\boldsymbol{{e}}}_{1}-\hat{\boldsymbol{{e}}}_{1}\hat{\boldsymbol{{X}}}\hat{\boldsymbol{{x}}}-\mathbf{\hat w} \boldsymbol{\hat x} + \hat{\boldsymbol{{x}}}\hat{\boldsymbol{{X}}}\hat{\boldsymbol{{e}}}_{1},\\[6pt] \left(\begin{array}{c@{\quad}c} \left(\boldsymbol{{c}}'\right)^{T} & \left(\boldsymbol{\tau }'\right)^{T} \end{array}\right)=\boldsymbol{{V}}^{T}\boldsymbol{{h}}_{6},\ \boldsymbol{{h}}_{6}=\left(\begin{array}{c@{\quad}c} \boldsymbol{{h}}_{c1}^{T} & \boldsymbol{{h}}_{\tau 1}^{T}\\[3pt] \boldsymbol{{h}}_{c2}^{T} & \boldsymbol{{h}}_{\tau 2}^{T} \end{array}\right) \end{array} \end{equation}
3. Workspace of couple-constrained parallel wrist with three flexible fingers
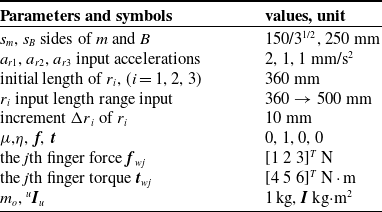
The parameters of the parallel wrist are listed in Table I.
Parameters of couple-constrained parallel wrist.

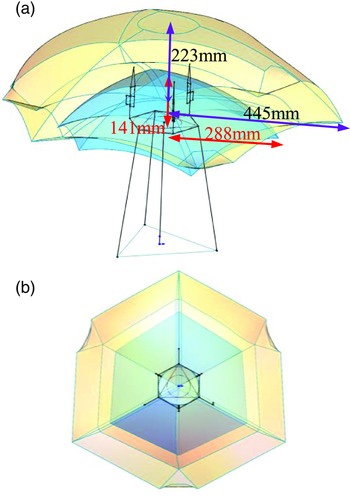
The reachable workspace of the gripper is an important index to evaluate its operation performance. A reachable workspace of the gripper is constructed, see Fig. 3.
Reachable workspaces of couple-constrained parallel wrist with three flexible fingers at fingertips. A isometric view with dimensions (a). A top view (b).

Since the couple-constrained parallel wrist has a symmetry structure in OYZ plane, its reachable workspace is also symmetry in OXZ plane. Let {r imax, r imin, Δr i (i = 1, 2, 3)} be (the maximum extension, the maximum extension, and the increment from r imin to r imax) of r i , respectively. Let {r wrjmax, r wrjmin, Δr wrj (j = 1, 2, 3)} be (the maximum extension, the maximum extension and the increment from r wrjmin to r wrjmax) of r wrj , respectively. In the light of the basic parameters listed in Table I, the reachable workspace W of the gripper is constructed using Matlab and is transformed into Solidwork using CAD variation geometry [Reference Lu, Shi and Hu23]. It is known from Fig. 3 that the workspaces of the three finger equivalent mechanisms at the fingertips in the developed gripper are quite large.
4. Dynamics model of couple-constrained parallel wrist with three flexible fingers
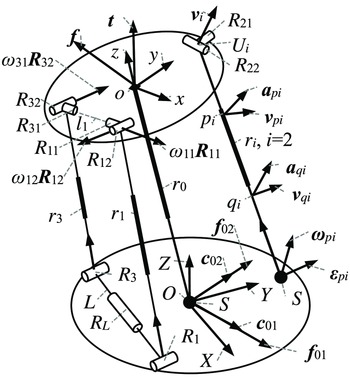
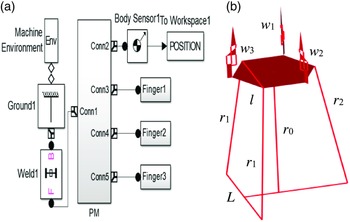
The kinematics of moving limbs r i are the pre-conditions of the dynamics analysis of the couple-constrained parallel wrist with three flexible fingers. Since the kinematics of r i are quite complicated, the derivation kinematics formulas of r i are explained in Appendix A. A dynamics model of the gripper is shown in Fig. 4. Some symbols for establishing the dynamics model are explained as follows.
Dynamics model of limbs r i (i = 0, 1, 2, 3).

Let g
i
be the piston rod as g = p or the cylinder as g = q in r
i
. Each of the limbs r
i
(i = 0, 1, 2, 3) is composed of a piton rod with its mass center p
i
and a cylinder with its mass center q
i
. Let
a
gi
be the translational acceleration of the moving link g
i
in r
i
at its mass center in {B}. Let
 $\boldsymbol{\varepsilon}$
i
angular velocity acceleration of r
i
. Let
J
gi
(g = p, q) be the Jacobian matrix of the moving link g
i
in r
i
. Let
V
gi
and
A
gi
be the general velocity and the general acceleration of g
i
in r
i
(i = 0, 1, 2, 3). The formulas for solving {
a
gi
,
 $\boldsymbol{\varepsilon}$
i
,
J
gi
(g = p, q),
V
gi
,
A
gi
} are derived in Appendix A.
Let f u , t u , m u , I u , G u {(u = o, p i , q i ; i = 0, 1, 2, 3)} be the inertial force, inertial torque, the mass, the inertial moment, the gravity of the moving links at their mass centers in {B}, respectively. Let ( f , t ) be the working-load wrench applied on m p at o. Let ( f d , t d ) be the damping force and torque applied on m p at o, respectively. Let μ be a damping coefficient. The formulas for solving ( f u , t u , G u , I u , f d , t d ) are represented as
 \begin{equation} \begin{array}{l} \left(\begin{array}{l} \boldsymbol{{f}}_{u}\\ \boldsymbol{{t}}_{u} \end{array}\right)=-\boldsymbol{{M}}_{u}\boldsymbol{{A}}_{u}-\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{\omega }_{u}\times \left(\boldsymbol{{I}}_{u}\boldsymbol{\omega }_{u}\right) \end{array}\right)\!, \boldsymbol{{M}}_{u}=\left(\begin{array}{c@{\quad}c} m_{u}\boldsymbol{{I}} & 0\\ 0 & \boldsymbol{{I}}_{u} \end{array}\right)\!, \\[9pt] \begin{array}{l} \boldsymbol{{G}}_{u}=m_{u}\,\boldsymbol{{g}},\ \boldsymbol{{f}}_{u}=-m_{u}\,\boldsymbol{{a}}_{u}, \left\{u=m,p_{i},q_{i},\left(i=0,1,2,3\right)\right\}\!, \\[3pt] \boldsymbol{{t}}_{u}=-\boldsymbol{{I}}_{u}\boldsymbol{\varepsilon }_{u}-\boldsymbol{\omega }_{u}\times \left(\boldsymbol{{I}}_{u}\boldsymbol{\omega }_{u}\right)\!, \ \boldsymbol{{f}}_{d}=-\mu \boldsymbol{{v}},\ \boldsymbol{{t}}_{d}=-\mu \boldsymbol{\omega } \end{array} \end{array} \end{equation}
Let
 ${f}_{ai}$
(i = 1, 2, 3) be the scalar of the input actuation force along r
i
. Let f
j
(j = 1, 2, 3) be the scalar of the input actuation forces of the jth finger. Let f
c
be the scalar of the constrained force exerted on m
p
of the parallel wrist, see Fig. 3. Let
F
r
be the general actuation/constrained forces of the developed parallel wrist and the three fingers. Let
V
f
be the general input velocity of the three finger mechanisms. Let
V
r
be the general input velocity of the developed parallel wrist and the three fingers. They are represented in {B} based on Eq. (11) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{V}}_{r}=\left(\begin{array}{l} \boldsymbol{{V}}_{pr}\\ \boldsymbol{{V}}_{f} \end{array}\right)\!, \ \boldsymbol{{F}}_{r}=\left(\begin{array}{l} \boldsymbol{{F}}_{pr}\\ \boldsymbol{{F}}_{f} \end{array}\right)\!, \ \boldsymbol{{V}}_{f}=\left(\begin{array}{l} {y^{\prime}}_{\!\!1}\\ y^{\prime}_{\!\!2}\\ y^{\prime}_{\!\!3} \end{array}\right)\!, \ \boldsymbol{{F}}_{f}=\left(\begin{array}{l} f_{1}\\ f_{2}\\ f_{3} \end{array}\right)\!, \\[16pt] \begin{array}{l} \boldsymbol{{V}}_{pr}=\left(\begin{array}{c@{\quad}c@{\quad}c@{\quad}c@{\quad}c@{\quad}c} v_{r1} & v_{r2} & v_{r3} & 0 & 0 & 0 \end{array}\right)^{T},\\[3pt] \boldsymbol{{F}}_{pr}=\left(\begin{array}{c@{\quad}c@{\quad}c@{\quad}c@{\quad}c@{\quad}c} f_{a1} & f_{a2} & f_{a3} & f_{c01} & f_{c02} & f_{c} \end{array}\right)^{T} \end{array} \end{array} \end{equation}
Let ( f wj , t wj ) be the working-load wrench applied on the jth fingertip w j . Let V wj be the general velocity of the jth fingertip w j in {B}. When ignoring the friction of all the joints in the mechanism, f and t are applied onto m p , based on the principle of virtual work, a power equation is derived as
 \begin{equation} \begin{array}{l} \boldsymbol{{V}}_{r}^{T}\boldsymbol{{F}}_{r}+\boldsymbol{{V}}^{T}\left(\begin{array}{c} \boldsymbol{{f}}+\boldsymbol{{f}}_{o}+\boldsymbol{{g}}_{o}+\boldsymbol{{f}}_{d}\\ \boldsymbol{{t}}+\boldsymbol{{t}}_{o}+\boldsymbol{{t}}_{d} \end{array}\right)+\boldsymbol\sum _{j=1}^{3}\boldsymbol{{V}}_{wj}^{T}\left(\begin{array}{c} \boldsymbol{{f}}_{wj}\\ \boldsymbol{{t}}_{wj} \end{array}\right)\\[8pt] +\boldsymbol\sum _{i=0}^{3}\left(\boldsymbol{{V}}_{pi}^{T}\left(\begin{array}{c} \boldsymbol{{f}}_{pi}+\boldsymbol{{g}}_{pi}\\ \boldsymbol{{t}}_{pi} \end{array}\right)+\boldsymbol{{V}}_{qi}^{T}\left(\begin{array}{c} \boldsymbol{{f}}_{qi}+\boldsymbol{{g}}_{qi}\\ \boldsymbol{{t}}_{qi} \end{array}\right)\right)=0 \end{array} \end{equation}
here, the items from the left to the right in Eq. (16) are the powers generated by F r , by ( f o , t o , g o ) of m and ( f , t ) and ( f d , t d ) applied on m p , by ( f wi , t wi ), and by ( f L , t L , g L ), respectively.
A formula for solving
 $\boldsymbol{{V}}_{wj}^{T}$
is represented as follows:
 \begin{equation} \boldsymbol{{V}}_{wj}^{T}=\boldsymbol{{V}}_{pr}^{T}\left(\boldsymbol{{J}}_{wj}\boldsymbol{{J}}^{-1}\right)^{T}+\boldsymbol{{V}}_{f}^{T}\left(_{tj}^{B}{\boldsymbol{{T}}}{}^{tj}{\boldsymbol{{J}}}{_{wrj}^{}}\boldsymbol{{J}}_{ej}\right)^{T} \end{equation}
here,
 $\boldsymbol{{V}}_{wj}^{T}$
is derived (Lu, et al. Reference Lu, Chang and Lu2021).
The relations V pr and V are represented based on Eqs. (11), (16) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{V}}_{r}^{T}\boldsymbol{{F}}_{r}=\boldsymbol{{V}}_{pr}^{T}\boldsymbol{{F}}_{pr}+\boldsymbol{{V}}_{f}^{T}\boldsymbol{{F}}_{f},\boldsymbol{{V}}^{T}=\boldsymbol{{V}}_{pr}^{T}\left(\boldsymbol{{J}}^{-1}\right)^{T},\\[6pt] \boldsymbol{{V}}_{gi}^{T}=\boldsymbol{{V}}^{T}\boldsymbol{{J}}_{gi}^{T}=\boldsymbol{{V}}_{pr}^{T}\left(\boldsymbol{{J}}^{-1}\right)^{T}\boldsymbol{{J}}_{gi}^{T},\left(g=p,q\right) \end{array} \end{equation}
Considering the friction of the joints in the mechanism, the efficiency (
 $\eta$
≤ 1) of the developed gripper can be added here. Thus, the formulas for solving the general dynamic actuation forces and the dynamic constrained forces are derived by substitute Eqs. (17), (18) into Eq. (16) as
 \begin{equation} \boldsymbol{{F}}_{f}=-\frac{1}{\eta }\sum _{j=1}^{3}\left(_{tj}^{B}{\boldsymbol{{T}}}{}^{tj}{\boldsymbol{{J}}}{_{wrj}^{}}\boldsymbol{{J}}_{Ej}\right)^{T}\left(\begin{array}{l} \boldsymbol{{f}}_{\mathit{wj}}\\ \boldsymbol{{t}}_{\mathit{wj}} \end{array}\right)\!, \end{equation}
 \begin{equation} \begin{array}{l} \displaystyle\boldsymbol{{F}}_{pr}=-\left(\boldsymbol{{J}}^{-1}\right)^{T}\left\{\frac{1}{\eta } \left(\left(\begin{array}{c} \boldsymbol{{f}}\\ \boldsymbol{{t}} \end{array}\right)-\mu \boldsymbol{{V}}-\boldsymbol{{M}}_{\!o}\boldsymbol{{A}}+\left(\begin{array}{c} m_{o}\boldsymbol{{g}}\\ -\boldsymbol{\omega }_{o}\times \left(\boldsymbol{{I}}_{o}\boldsymbol{\omega }_{o}\right) \end{array}\right)\right)\right.\\[10pt] \qquad \ \ +\mathop{\sum}\limits_{i=0}^{3}\boldsymbol{{J}}_{pi}^{T}\left(-\boldsymbol{{M}}_{pi}\boldsymbol{{A}}_{pi}+\left(\begin{array}{c} m_{pi}\boldsymbol{{g}}\\ -\boldsymbol{\omega }_{i}\times \left(\boldsymbol{{I}}_{pi}\boldsymbol{\omega }_{i}\right) \end{array}\right)\right)\\[10pt] \qquad \ \ \left. +\mathop{\sum}\limits_{i=0}^{3}\boldsymbol{{J}}_{qi}^{T}\left(-\boldsymbol{{M}}_{qi}\boldsymbol{{A}}_{qi}+\left(\begin{array}{c} m_{qi}\boldsymbol{{g}}\\ -\boldsymbol{\omega }_{i}\times \left(\boldsymbol{{I}}_{qi}\boldsymbol{\omega }_{i}\right) \end{array}\right)\right)+\sum _{j=1}^{3}\left(\boldsymbol{{J}}_{wj}\right)^{T}\left(\begin{array}{c} \boldsymbol{{f}}_{\mathit{wj}}\\ \boldsymbol{{t}}_{\mathit{wj}} \end{array}\right)\right\} \end{array} \end{equation}
The formulae for solving the dynamic couple-constrained forces
 $f_{ci}$
(i = 1, 3) and the dynamic constrained torque t
c
exerted on to L are derived by utilizing Eqs. (7), (19b) as follows:
 \begin{equation} \begin{array}{l} \displaystyle f_{c}=f_{c1}+f_{c3},f_{c1}=\frac{f_{c}}{1+k},f_{c3}=f_{c}-f_{c1},\\[3pt] \displaystyle t_{c}=\left(\boldsymbol{{r}}_{1}\times f_{c1}\boldsymbol{{c}}_{1}\right)\cdot \boldsymbol{{X}},k=\left(\boldsymbol{{r}}_{1}\times \boldsymbol{{c}}_{1}\right)\cdot \boldsymbol{{x}}/\left[\left(\boldsymbol{{r}}_{3}\times \boldsymbol{{c}}_{1}\right)\cdot \boldsymbol{{x}}\right] \end{array} \end{equation}
5. Theoretical solutions of kinematics/dynamics
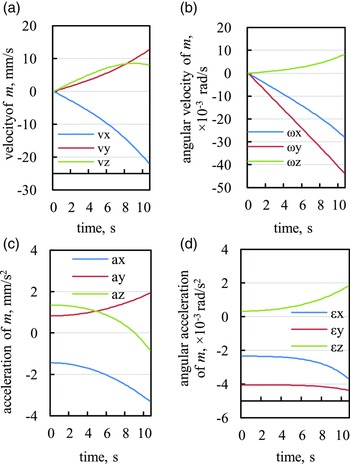
A program is compiled using Matlab based on the theoretical formulas in Sections 2, 4 and Appendix A. Theoretical kinematics solutions of m p of parallel wrist are solved, see Fig. 5.
Theoretical kinematics solutions of the moving platform m p of couple-constrained parallel wrist with three force flexible fingers.

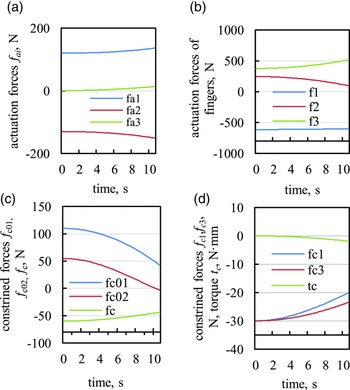
The dynamic actuation forces
 ${f}_{ai}$
(i = 1, 2, 3) of the parallel wrist are solved, see Fig. 6a. The dynamic actuation forces f
j
(j = 1, 2, 3) of the fingers are solved, see Fig. 6b. The dynamic constrained forces f
c0i
(i = 1, 2) of the parallel wrist exerted on r
0 are solved, see Fig. 6c. The dynamic constrained forces
 $f_{ci}$
(i = 1, 3) of the parallel wrist exerted on L and the dynamic constrained torque t
c
are solved, see Fig. 6d.
Theoretical dynamics solutions of dynamic actuation forces, the dynamic constrained forces, and torque of parallel wrist.

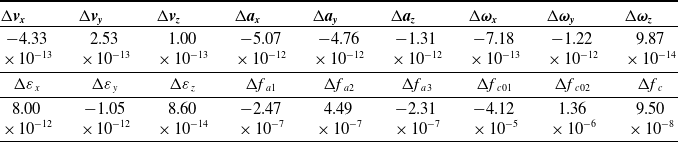
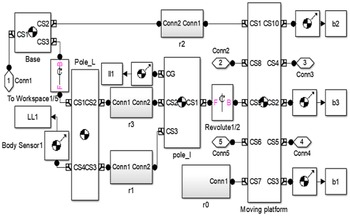
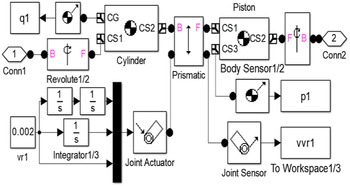
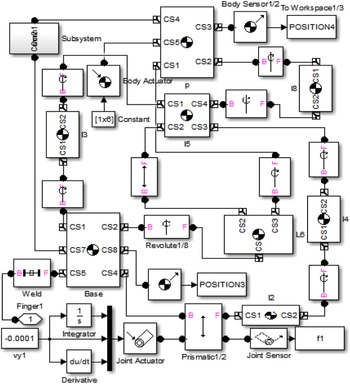
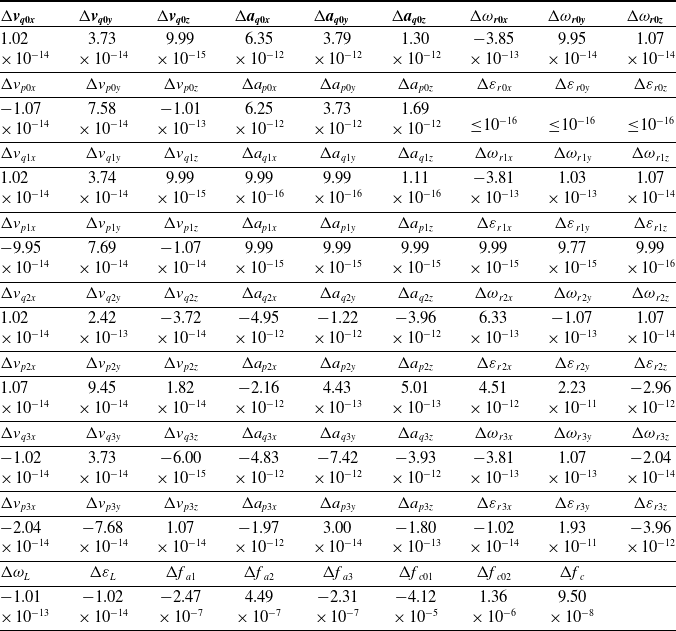
In order to verify the correctness of the theoretical solutions of the gripper, an equivalent simulation mechanism of the gripper with three fingers and a logical block of RPR-type actuation limbs r 1 and r 3, a logical block of SPU type actuation limb r 2 are constructed, respectively, using Matlab/Simulink/Mechanics, see Appendix B. The absolution errors Δx between the maximum theoretical solutions x and the maximum simulation solutions x s are listed in Table II and Table A1. It is known from Table II that the theoretical solutions coincide with that of the simulation mechanism. Hence, the derived formulas in Sections 2, 3, and Appendix A are correct.
Absolute errors Δx = abs(x-x s ) between the maximum theoretical solutions x and the maximum simulation solutions x s .

6. Experiment of prototype of couple-constrained parallel wrist with three flexible fingers
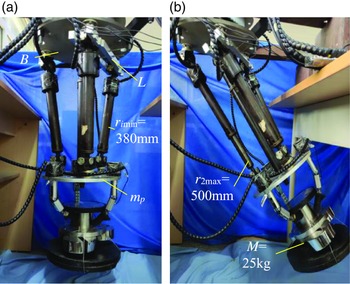
Two poses of prototype of couple-constrained parallel wrist with three flexible fingers are shown in Fig. 7a, b.
Prototype of couple-constrained parallel wrist with three flexible fingers for grabbing object M = 25 kg in two poses as r i = r imin (i = 1, 2, 3) (a), and as r 2 = r 2max, r 1 = r 3 = r imin (b).

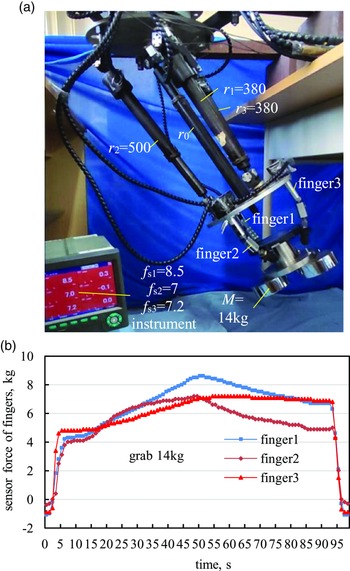
Let r imin (i = 1, 2, 3) and r imax be the minimum and maximum extension of actuation limbs r i . Let M be the mass of the grabbed object. M is increased to 25 kg, see Fig. 7b. Let f si be measured forces of sensor of fingers i. A measured system is built to measure f si as grabbing object with different masses, see Fig. 8a. As grabbing object with M = 14 kg, the measured results of f si are shown in Fig. 8b.
Measured system of sensor forces f si of fingers in developed gripper as grabbing object with different masses (a), Measured results of f si as grabbing object with M = 14 kg (b).

It is known from the experiments the developed prototype of couple-constrained parallel wrist with three measuring force flexible fingers that:
-
1. A heavy workload M = 25 kg can be grabbed and moved in the large workspace, see Fig. 3 and Fig. 7b.
-
2. A large grabbing impact can be reduced greatly using a pre-pressured spring installed in the finger, see Fig. 8b.
-
3. The measured forces f si are varied smoothly as grabbing the object with constant mass and moving smoothly. ( f s1, f s2, f s3) are different with each other, which are dependent on the grapping pose and the manufacturing precise of the finger, see Fig. 8b.
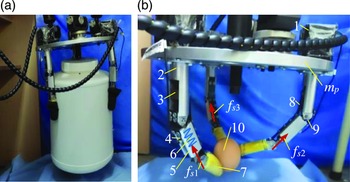
The measuring force flexible finger is formed by a screw motor 1 and a seat 2 fixed onto m p , a nut 3, a sensor 4, a sleeve 5, a spring 6 and a inner sleeve in sleeve, a fingertip link 7, a long slice 8, a short slice 9, see Fig. 9. A big heavy tub and an egg 10 can be grabbed, see Fig. 9.
A big heavy tub (a) and a easy breakage egg (b) grabbed by couple-constrained parallel wrist with three flexible fingers.

7. Conclusions
The developed novel couple-constrained parallel wrist has three DOFs and quite large workspace which is benefited to increase the dexterity of the gripper.
The couple-constrained parallel wrist with three measuring force flexible fingers can be used to grab the heavy objects with various shapes or large volume. It also can be used to grab the small and easy breakage object. A large grabbing impact can be reduced greatly using a pre-pressured spring installed in the finger.
The theoretical solutions of the kinematics and dynamics of the couple-constrained parallel wrist with three measuring force flexible fingers are verified to be correct by its simulation mechanism. These kinematics and dynamics models of the developed couple-constrained parallel wrist with three measuring force flexible fingers provide a theoretical foundation for analysis of the dynamics and stiffness of other grippers and their control.
Further study should be conducted on the synthesis and optimization of the kinematic parameters of the overall gripper mechanism in order to increase the grabbing capability and the dexterity of the gripper.
Author contributions
Yang Lu and Yi Lu conceived and designed the study and experiment. Zefeng Chang conducted data gathering and formulas dervation, and simulation verfication. Yi Lu wrote the article.
Financial support
The authors are grateful to Natural Science Foundation (grant number E2020203010) of Hebei, China.
Competing interest
We have no potential conflicts of interest.
Ethical standard
Not applicable, as this paper does not include any human and/or animal experimentation.
Appendix A
A. Kinematics of moving limbs r i
The kinematic models of the moving limbs r
i
are shown in Fig. 3. Let
v
i
(i = 1, 2, 3) be the translational velocity of r
i
at point b
i
in {B}. Let (
 $\boldsymbol{\omega}$
i
,
 $\boldsymbol{\varepsilon}$
i
) be the angular (velocity and acceleration) of r
i
in {B}. g
i
may be the piston rod as g = p or the cylinder as g = q in r
i
. The formulas of (
r
i
,
e
i
,
v
,
 $\boldsymbol{\omega}$
,
v
i
,
 $\boldsymbol{\omega}$
i
, v
i
) can be represented as follows:
 \begin{equation} \boldsymbol{{v}}_{i}=v_{ri}\boldsymbol{\delta }_{i}+\boldsymbol{\omega }_{i}\times \boldsymbol{{r}}_{i},\ \boldsymbol{{v}}_{i}=\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i},\boldsymbol{{v}}_{i}- v_{ri}\boldsymbol{\delta }_{i}=\boldsymbol{\omega }_{i}\times \boldsymbol{{r}}_{i} \end{equation}
The kinematics/statics formulas of the flexible finger have been derived by [Reference Lu, Ye and Chang21]. The kinematics formulas of the moving limbs r i (i = 0, 1, 2, 3) are derived as follows.
A.1. Angular velocity/acceleration of actuation limbs r i
Cross multiply both sides of the first formula in Eq. (A1) in the right by r i , it leads to
 \begin{equation} \begin{array}{l} \boldsymbol{\delta }_{i}\times \boldsymbol{{v}}_{i}=\boldsymbol{\delta }_{i}\times v_{ri}\boldsymbol{\delta }_{i}+r_{i}\boldsymbol{\delta }_{i}\times \left(\boldsymbol{\omega }_{i}\times \boldsymbol{\delta }_{i}\right)\\[3pt] =r_{i}\boldsymbol{\delta }_{i}\times \left(\boldsymbol{\omega }_{i}\times \boldsymbol{\delta }_{i}\right)=r_{i}\boldsymbol{\omega }_{i}-r_{i}\left(\boldsymbol{\delta }_{i}\cdot \boldsymbol{\omega }_{i}\right)\boldsymbol{\delta }_{i} \end{array} \end{equation}
The upper ends of r
i
(i = 1, 2, 3) are connected with m by U
i
at b
i
, U
i
is formed by two crossed revolute joints R
ij
(j = 1, 2), and (R
i1
 $\perp$
R
i2, R
i1
 $\perp$
z, R
i2
 $\perp$
r
i
, R
11|R
31) are satisfied. Let
R
ij
be the unit vector of R
ij
. The angular velocities
 $\boldsymbol{\omega}$
i
(i = 1, 2, 3) of r
i
are satisfied as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{\omega }_{i}+\theta '_{\!\!i1}\boldsymbol{{R}}_{i1}+\theta '_{\!\!i2}\boldsymbol{{R}}_{i2}=\boldsymbol{\omega },\\[3pt] \boldsymbol{{R}}_{i2}=\boldsymbol{{R}}_{i1}\times \boldsymbol{{r}}_{i}/\boldsymbol{|}\boldsymbol{{R}}_{i1}\times \boldsymbol{{r}}_{i}\boldsymbol{|},\left(i=1,2,3\right) \end{array} \end{equation}
here, θʹ ij (i = 1, 2, 3; j = 1, 2) are the scalar angular speeds of r i about R ij .
Cross multiply both sides of Eq. (A3) in the right by r i , it leads to
 \begin{equation} \begin{array}{l} \boldsymbol{\omega }\times \boldsymbol{{r}}_{i}-\theta '_{\!\!i1}\boldsymbol{{R}}_{i1}\times \boldsymbol{{r}}_{i}-\theta '_{\!\!i2}\boldsymbol{{R}}_{i2}\times \boldsymbol{{r}}_{i}=\boldsymbol{\omega }_{i}\times \boldsymbol{{r}}_{i}\\[3pt] =\boldsymbol{{v}}_{i}-v_{ri}\boldsymbol{\delta }_{i}=\boldsymbol{{v}}_{i}-\left(\boldsymbol{{v}}_{i}\cdot \boldsymbol{\delta }_{i}\right)\boldsymbol{\delta }_{i}=-\hat{\boldsymbol{\delta }}_{i}^{2}\left(\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i}\right) \end{array} \end{equation}
Dot multiply both sides of Eq. (A4) in the right by R i1 and R i2, respectively, it leads to
 \begin{equation} \begin{array}{l} \left(\boldsymbol{\omega }\times \boldsymbol{{r}}_{i}\right)\cdot \boldsymbol{{R}}_{i1}-\left(\theta '_{\!\!i2}\boldsymbol{{R}}_{i2}\times \boldsymbol{{r}}_{i}\right)\cdot \boldsymbol{{R}}_{i1}=\hat{\boldsymbol{\delta }}_{i}^{2}\left(-\boldsymbol{{v}}+\hat{\boldsymbol{{e}}}_{i}\boldsymbol{\omega }\right)\cdot \boldsymbol{{R}}_{i1},\\[6pt]\left(\boldsymbol{\omega }\times \boldsymbol{{r}}_{i}\right)\cdot \boldsymbol{{R}}_{i2}-\left(\theta '_{\!\!i1}\boldsymbol{{R}}_{i1}\times \boldsymbol{{r}}_{i}\right)\cdot \boldsymbol{{R}}_{i2}=\hat{\boldsymbol{\delta }}_{i}^{2}\left(-\boldsymbol{{v}}+\hat{\boldsymbol{{e}}}_{i}\boldsymbol{\omega }\right)\cdot \boldsymbol{{R}}_{i2} \end{array} \end{equation}
The formulas of θʹ i1 and θʹ i2 are derived from Eq. (A5) as
 \begin{equation} \begin{array}{l} \theta '_{\!\!i1}=\left[-\left(\hat{\boldsymbol{{r}}}_{i}\boldsymbol{{R}}_{i2}\right)\cdot \boldsymbol{\omega }-\hat{\boldsymbol{\delta }}_{i}^{2}\left(\boldsymbol{{v}}-\hat{\boldsymbol{{e}}}_{i}\boldsymbol{\omega }\right)\cdot \boldsymbol{{R}}_{i2}\right]/d_{i1},\\[6pt] \theta '_{\!\!i2}=\left[\left(\hat{\boldsymbol{{r}}}_{i}\boldsymbol{{R}}_{i1}\right)\cdot \boldsymbol{\omega }+\hat{\boldsymbol{\delta }}_{i}^{2}\left(\boldsymbol{{v}}-\hat{\boldsymbol{{e}}}_{i}\boldsymbol{\omega }\right)\cdot \boldsymbol{{R}}_{i1}\right]/d_{i1},\\[6pt] d_{i1}=\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)\cdot \boldsymbol{{r}}_{i} \end{array} \end{equation}
Substitute Eqs. (A6) for Eq. (A5), a formula for solving
 $\boldsymbol{\omega}$
i
is derived from Eq. (A3) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{\omega }_{i}=\boldsymbol{\omega }-\boldsymbol{{R}}_{i1}\theta '_{\!\!i1}-\boldsymbol{{R}}_{i2}\theta '_{\!\!i2}\\[6pt] =\boldsymbol{\omega }+\boldsymbol{{R}}_{i1}\left[\boldsymbol{{R}}_{i2}^{T}\left(\boldsymbol{\omega }\times \boldsymbol{{r}}_{i}\right)+\boldsymbol{{R}}_{i2}^{T}\hat{\boldsymbol{\delta }}_{i}^{2}\left(\boldsymbol{{v}}-\hat{\boldsymbol{{e}}}_{i}\boldsymbol{\omega }\right)\right]/d_{i1}\\[6pt] -\boldsymbol{{R}}_{i2}\left[\boldsymbol{{R}}_{i1}^{T}\left(\boldsymbol{\omega }\times \boldsymbol{{r}}_{i}\right)+\boldsymbol{{R}}_{i1}^{T}\hat{\boldsymbol{\delta }}_{i}^{2}\left(\boldsymbol{{v}}-\hat{\boldsymbol{{e}}}_{i}\boldsymbol{\omega }\right)\right]/d_{i1},\\[6pt] \boldsymbol{\omega }_{i}=\boldsymbol{\omega }-\boldsymbol{{d}}_{i2}\left[\left(r_{i}\hat{\boldsymbol{\delta }}_{i}\boldsymbol{\omega }\right)-\hat{\boldsymbol{\delta }}_{i}^{2}\left(\boldsymbol{{v}}-\hat{\boldsymbol{{e}}}_{i}\boldsymbol{\omega }\right)\right]/d_{i1},\\[6pt] \boldsymbol{{d}}_{i2}=\boldsymbol{{R}}_{i1}\boldsymbol{{R}}_{i2}^{T}-\boldsymbol{{R}}_{i2}\boldsymbol{{R}}_{i1}^{T},d_{i1}=\boldsymbol{{r}}_{i}\cdot \left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right) \end{array} \end{equation}
Eq. (A7) is simplified as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{\omega }_{i}=\left(\boldsymbol{{J}}_{\omega i}\right)_{3\times 6}\boldsymbol{{V}},\boldsymbol{{J}}_{\omega i}=\left(\begin{array}{c@{\quad}c} \boldsymbol{{J}}_{\omega i1} & \boldsymbol{{J}}_{\omega i2} \end{array}\right)/d_{i1},\\[6pt] \boldsymbol{{J}}_{\omega i1}=\boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}^{2}, \boldsymbol{{R}}_{i2}=\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{r}}_{i}\right)/|\boldsymbol{{R}}_{i1}\times \boldsymbol{{r}}_{i}|, \\[6pt] \boldsymbol{{J}}_{\omega i2}=d_{i1}\boldsymbol{{I}}-\boldsymbol{{d}}_{i2}\left(\hat{\boldsymbol{{r}}}_{i}+\hat{\boldsymbol{\delta }}_{i}^{2}\hat{\boldsymbol{{e}}}_{i}\right)=d_{i1}\boldsymbol{{I}}-\boldsymbol{{d}}_{i2}\hat{\boldsymbol{{r}}}_{i}-\boldsymbol{{J}}_{\omega i1}\hat{\boldsymbol{{e}}}_{i} \end{array} \end{equation}
The items {
 $\boldsymbol{{d}}_{i2}, \boldsymbol{{r}}_{i}\cdot (\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2})', \boldsymbol{{d}}_{i2}{\hat{\boldsymbol{{r}}}{'}}_{\!\!i}, d'_{\!\!i1}$
} for solving
 $\boldsymbol{\varepsilon}$
i
are derived as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{R}}_{i1}\cdot \boldsymbol{{R}}_{i2}=0,\boldsymbol{{R}}'_{\!\!i1}=\boldsymbol{\omega }\times \boldsymbol{{R}}_{i1},\boldsymbol{{R}}'_{\!\!i2}=\boldsymbol{\omega }_{i}\times \boldsymbol{{R}}_{i2}, \\[6pt] \boldsymbol{{d}}_{i2}=\boldsymbol{{R}}_{i1}\boldsymbol{{R}}_{i2}^{T}-\boldsymbol{{R}}_{i2}\boldsymbol{{R}}_{i1}^{T}=s\left(\boldsymbol{{R}}_{i2}\times \boldsymbol{{R}}_{i1}\right)\!, \boldsymbol{{R}}_{i2}\cdot \boldsymbol{{r}}_{i}=0,\\[6pt] \left[\left(\boldsymbol{{R}}_{i2}\times \boldsymbol{{R}}_{i1}\right)^\prime\right]^{T}=\left(\boldsymbol{{R}}'_{\!\!i2}\times \boldsymbol{{R}}_{i1}+\boldsymbol{{R}}_{i2}\times \boldsymbol{{R}}'_{\!\!i1}\right)^{T}\\[6pt] =\left(\boldsymbol{\omega }_{i}\cdot \boldsymbol{{R}}_{i1}\right)\boldsymbol{{R}}_{i2}^{T}-\left(\boldsymbol{\omega }\cdot \boldsymbol{{R}}_{i2}\right)\boldsymbol{{R}}_{i1}^{T}=\boldsymbol{\omega }_{i}^{T}\boldsymbol{{R}}_{i1}\boldsymbol{{R}}_{i2}^{T}-\boldsymbol{\omega }^{T}\boldsymbol{{R}}_{i2}\boldsymbol{{R}}_{i1}^{T}, \end{array} \end{equation}
 \begin{equation*} \begin{array}{l} \boldsymbol{{r}}_{i}\cdot \left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)^\prime=-\boldsymbol{{r}}_{i}\cdot \left(\boldsymbol{{R}}_{i2}\times \boldsymbol{{R}}_{i1}\right)^\prime\\[6pt] =-\left(\boldsymbol{\omega }_{i}\cdot \boldsymbol{{R}}_{i1}\right)\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i2}\right)+\left(\boldsymbol{{R}}_{i2}\cdot \boldsymbol{\omega }\right)\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i1}\right)\\[2pt] =\boldsymbol{\omega }^{T}\boldsymbol{{R}}_{i2}\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i1}\right)\!, \boldsymbol{{d}}_{i2}{\hat{\boldsymbol{{r}}}'}_{\!\!i}=-\left(\boldsymbol{{r}}'_{\!\!i}\right)^{T}\left(\boldsymbol{{d}}_{i2}\boldsymbol{{C}}\right)=-\boldsymbol{{V}}^{T}\left(\begin{array}{l} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left(\boldsymbol{{d}}_{i2}\boldsymbol{{C}}\right)\!, \\[10pt] d'_{\!\!i1}=\left[\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)\cdot \boldsymbol{{r}}_{i}\right]\!'=\boldsymbol{{r}}'_{\!\!i}\cdot \left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)+\boldsymbol{{r}}_{i}\cdot \left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)^\prime\\[6pt] =\left(\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i}\right)^{T}\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)+\boldsymbol{\omega }^{T}\boldsymbol{{R}}_{i2}\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i1}\right)\\[6pt]=\boldsymbol{{V}}^{T}\left[\left(\begin{array}{l} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)+\left(\begin{array}{l} \boldsymbol{0}\\ \boldsymbol{{I}} \end{array}\right)\boldsymbol{{R}}_{i2}\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i1}\right)\right] \end{array} \end{equation*}
The items
 $ \{\boldsymbol{{d}}'_{\!\!i2}, \boldsymbol{{d}}_{i2}{\hat{\boldsymbol{\delta }}'}_{\!\!i}, \boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}^{2}{\hat{\boldsymbol{{e}}}'}_{\!\!i}, \boldsymbol{{d}}_{i2}(\hat{\boldsymbol{\delta }}_{i}^{2})'\}$
for solving
 $\boldsymbol{\varepsilon}$
i
are derived from Eq. (A9) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{d}}'_{\!\!i2}=s\left(\boldsymbol{{R}}_{i2}\times \boldsymbol{{R}}_{i1}\right)^\prime=\left[\left(\boldsymbol{{R}}_{i2}\times \boldsymbol{{R}}_{i1}\right)^\prime\right]^{T}\boldsymbol{{C}} \\[6pt] =\left[\left(\boldsymbol{\omega }_{i}^{T}\boldsymbol{{R}}_{i1}\right)\boldsymbol{{R}}_{i2}^{T}-\left(\boldsymbol{\omega }^{T}\boldsymbol{{R}}_{i2}\right)\boldsymbol{{R}}_{i1}^{T}\right]\boldsymbol{{C}}=\boldsymbol{{V}}^{T}\left\{\left[\left(\boldsymbol{{J}}_{\omega i}^{T}\boldsymbol{{R}}_{i1}\right)\boldsymbol{{R}}_{i2}^{T}-\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{{R}}_{i2}\boldsymbol{{R}}_{i1}^{T} \end{array}\right)\right]\boldsymbol{{C}}_{e}\right\}\!, \end{array} \end{equation}
 \begin{equation*} \begin{array}{l} \boldsymbol{{d}}_{i2}{\hat{\boldsymbol{\delta }}{'}}_{\!\!i}=-\left(\boldsymbol{\delta }'_{\!\!i}\right)^{T}\boldsymbol{{d}}_{i2}\boldsymbol{{C}}=\frac{\boldsymbol{{V}}^{T}}{r_{i}}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}^{2}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i}^{2} \end{array}\right)\left(\boldsymbol{{d}}_{i2}\boldsymbol{{C}}\right)\!, \\[10pt] \boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}^{2}{\hat{\boldsymbol{{e}}}{'}}_{\!\!i}=-\left(\boldsymbol{{e}}'_{\!\!i}\right)^{T}\left[\left(\boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}^{2}\right)\boldsymbol{{C}}\right]=-\boldsymbol{{V}}^{T}\left(\begin{array}{c} \boldsymbol{0}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left[\left(\boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}^{2}\right)\boldsymbol{{C}}\right],\\[6pt] \boldsymbol{{d}}_{i2}\left(\hat{\boldsymbol{\delta }}_{i}^{2}\right)^\prime=\boldsymbol{{d}}_{i2}\left({\hat{\boldsymbol{\delta }}{'}}_{\!\!i}\hat{\boldsymbol{\delta }}_{i}+\hat{\boldsymbol{\delta }}_{i}{\hat{\boldsymbol{\delta }}{'}}_{\!\!i}\right)=-\left(\boldsymbol{\delta }'_{\!\!i}\right)^{T}\left[\boldsymbol{{d}}_{i2}\boldsymbol{{C}}\hat{\boldsymbol{\delta }}_{i}+\left(\boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}\right)\boldsymbol{{C}}\right]\\[6pt] \ \ \quad\qquad=\boldsymbol{{V}}^{T}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}^{2}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i}^{2} \end{array}\right)\dfrac{\left[\boldsymbol{{d}}_{i2}\boldsymbol{{C}}\hat{\boldsymbol{\delta }}_{i}+\left(\boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}\right)\boldsymbol{{C}}\right]}{r_{i}} \end{array} \end{equation*}
Next, the formulas for solving
 $\boldsymbol{\varepsilon}$
i
are derived from Eqs. (A9) and (A10) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{\varepsilon }_{i}=\boldsymbol{\omega }'_{\!\!i}=\boldsymbol{{J}}_{\omega i}\boldsymbol{{A}}+\boldsymbol{{J}}'_{\!\!\omega i}\boldsymbol{{V}},\boldsymbol{{J}}'_{\!\!\omega i}=\left[\left(\begin{array}{c@{\quad}c} \boldsymbol{{J}}'_{\!\!\omega i1} & \boldsymbol{{J}}'_{\!\!\omega i2} \end{array}\right)-d'_{\!\!i1}\boldsymbol{{J}}_{\omega i}\right]/d_{i1}=\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{\omega i},\\[6pt] \boldsymbol{{J}}'_{\!\!\omega i1}=\left(\boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}^{2}\right)^\prime=\boldsymbol{{d}}'_{\!\!i2}\hat{\boldsymbol{\delta }}_{i}^{2}+\boldsymbol{{d}}_{i2}\left(\hat{\boldsymbol{\delta }}_{i}^{2}\right)^\prime=\boldsymbol{{V}}^{T}\boldsymbol{{h}}_{\omega i1}, \\[6pt] \boldsymbol{{h}}_{\omega i1}=\left(\boldsymbol{{J}}_{\omega i}^{T}\boldsymbol{{R}}_{i1}\boldsymbol{{R}}_{i2}^{T}-\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{{R}}_{42}\boldsymbol{{R}}_{41}^{T} \end{array}\right)\right)\boldsymbol{{C}}_{e}\hat{\boldsymbol{\delta }}_{i}^{2}+\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}^{2}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i}^{2} \end{array}\right)\dfrac{\left(\boldsymbol{{d}}_{i2}\boldsymbol{{C}}\right)\hat{\boldsymbol{\delta }}_{i}+\left(\boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}\right)\boldsymbol{{C}}}{r_{i}} \end{array} \end{equation}
 \begin{equation*} \begin{array}{l} \boldsymbol{{J}}'_{\!\!\omega i2}=\left(d_{i1}\boldsymbol{{I}}-\boldsymbol{{d}}_{i2}\hat{\boldsymbol{{r}}}_{i}-\boldsymbol{{J}}_{\omega i1}\hat{\boldsymbol{{e}}}_{i}\right)^\prime\\[6pt] =d'_{\!\!i1}\boldsymbol{{I}}-\boldsymbol{{d}}'_{\!\!i2}\hat{\boldsymbol{{r}}}_{i}-\boldsymbol{{d}}_{i2}{\hat{\boldsymbol{{r}}}{'}}_{\!\!i}-\boldsymbol{{J}}_{\omega i1}{\hat{\boldsymbol{{e}}}{'}}_{\!\!i}-\boldsymbol{{J}}'_{\!\!\omega i1}\hat{\boldsymbol{{e}}}_{i}=\boldsymbol{{V}}^{T}\boldsymbol{{h}}_{\omega i2},\\[6pt] \boldsymbol{{h}}_{\omega i2}=\left(\begin{array}{c} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left[\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)\boldsymbol{{I}}\boldsymbol{+}\boldsymbol{{d}}_{i2}\boldsymbol{{C}}\right]+\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{{I}} \end{array}\right)\boldsymbol{{R}}_{i2}\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i1}\right)\boldsymbol{{I}} \\[10pt] -\left[\left(\boldsymbol{{J}}_{\omega i}^{T}\boldsymbol{{R}}_{i1}\right)\boldsymbol{{R}}_{i2}^{T}-\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{{R}}_{i2}\boldsymbol{{R}}_{i1}^{T} \end{array}\right)\right]\boldsymbol{{C}}_{e}\hat{\boldsymbol{{r}}}_{i}+\left(\begin{array}{c} \boldsymbol{0}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left(\boldsymbol{{J}}_{\omega i1}\boldsymbol{{C}}\right)-\boldsymbol{{h}}_{\omega i1}\hat{\boldsymbol{{e}}}_{i},\\[10pt] \boldsymbol{{H}}_{\omega i}=\dfrac{1}{d_{i1}}\left\{\left(\begin{array}{c@{\quad}c} \boldsymbol{{h}}_{\omega i1} & \boldsymbol{{h}}_{\omega i2} \end{array}\right)-\left[\left(\begin{array}{c} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)+\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{{I}} \end{array}\right)\boldsymbol{{R}}_{i2}\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i1}\right)\right]\boldsymbol{{J}}_{\omega i}\right\} \end{array} \end{equation*}
H
 $_{\omega i}$
is the 3 × 6 Hessian matrix mapped from
V
to
 $\boldsymbol{\varepsilon}$
i
.
A.2. Translational velocity and acceleration of r i
Each of the limbs r i (i = 1, 2, 3) is composed of a piton rod with its mass center p i and a cylinder with its mass center q i . Let v gi and a gi be, respectively, the translational velocity and the acceleration of the moving link g i in r i at its mass center in {B}, g = p for the piston rod, g = q for the cylinder. Let r i be the distance from B i to b i . Let l pi be the distance from b i to p i . Let l qi be the distance from B i to q i . The formulas for solving v gi are derived as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{v}}_{pi}=v_{ri}\boldsymbol{\delta }_{i}+ \boldsymbol{\omega }_{i}\times \left(r_{i}- l_{pi}\right)\boldsymbol{\delta }_{i}=\boldsymbol{{J}}_{vpi}\boldsymbol{{V}},\\[4pt] \boldsymbol{{J}}_{vpi}=\boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}\left(\begin{array}{c@{\quad}c} \boldsymbol{{I}} & - \hat{\boldsymbol{{e}}}_{i} \end{array}\right)- \left(r_{i}- l_{pi}\right)\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}_{\omega i},\\[4pt] \boldsymbol{{v}}_{qi}=\boldsymbol{\omega }_{i}\times l_{qi}\boldsymbol{\delta }_{i}=\boldsymbol{{J}}_{vqi}\boldsymbol{{V}},\boldsymbol{{J}}_{vqi}=- l_{qi}\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}_{\omega i} \end{array} \end{equation}
here, J vgi (g = p, q) is the translational Jacobian matrix of the moving link g i in r i .
In order to derive the formula for solving
a
gi
, several items
 $ \{ r^\prime_i, \boldsymbol{\delta}^\prime_i, {(\boldsymbol{\delta}^\prime_i)}^T, \boldsymbol{\delta}_i {(\boldsymbol{\delta}^\prime_i)}^T, \boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}{\hat{\boldsymbol{{e}}}{'}}_{\!\!i},\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}'_{\!\!\omega i}$
, (i = 1, 2, 3)} are derived as follows:
 \begin{equation} \begin{array}{l} r'_{\!\!i}=v_{ri}=\boldsymbol{{r}}'_{\!\!i}\cdot \boldsymbol{\delta }_{i}=\left(\boldsymbol{{r}}'_{\!\!i}\right)^{T}\boldsymbol{\delta }_{i}=\left(\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i}\right)^{T}\boldsymbol{\delta }_{i}\\[4pt] =\left[\left(\begin{array}{c@{\quad}c} \boldsymbol{{I}} & -\hat{\boldsymbol{{e}}}_{i} \end{array}\right)\boldsymbol{{V}}\right]^{T}\boldsymbol{\delta }_{i}=\boldsymbol{{V}}^{T}\left(\begin{array}{c} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\boldsymbol{\delta }_{i}=\boldsymbol{{V}}^{T}\left(\begin{array}{c} \boldsymbol{\delta }_{i}\\ \hat{\boldsymbol{{e}}}_{i}\boldsymbol{\delta }_{i} \end{array}\right)\!, \\[10pt] \boldsymbol{\delta }'_{\!\!i}=\left(\boldsymbol{{r}}_{i}/r_{i}\right)^\prime=-\left[\left(\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i}\right)\times \boldsymbol{\delta }_{i}\right]^{T}\boldsymbol{{C}}\boldsymbol{\delta }_{i}/r_{i}\\[4pt] =-\left[\boldsymbol{{V}}^{T}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i} \end{array}\right)\right]\boldsymbol{{C}}\dfrac{\boldsymbol{\delta }_{i}}{r_{i}}=-\dfrac{\boldsymbol{{V}}^{T}}{r_{i}}\left[\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i} \end{array}\right)\boldsymbol{{C}}_{e}\right]\boldsymbol{\delta }_{i},\\[2pt] {\hat{\boldsymbol{\delta }}{'}}_{\!\!i}=\left(\boldsymbol{\delta }'_{\!\!i}\right)^{T}\boldsymbol{{C}}=-\left(\boldsymbol{{V}}^{T}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}^{2}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i}^{2} \end{array}\right)\right)\dfrac{\boldsymbol{{C}}}{r_{i}}=-\boldsymbol{{V}}^{T}\left(\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}^{2}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i}^{2} \end{array}\right)\dfrac{\boldsymbol{{C}}_{e}}{r_{i}}\right)\!, \\[15pt] \boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}{\hat{\boldsymbol{{e}}}{'}}_{\!\!i}=-\left(\boldsymbol{{e}}'_{\!\!i}\right)^{T}\left[\left(\boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}\right)\boldsymbol{{C}}\right]=-\boldsymbol{{V}}^{T}\left(\begin{array}{c} \boldsymbol{0}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left[\left(\boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}\right)\boldsymbol{{C}}\right],\\[15pt] \end{array} \end{equation}
 \begin{equation*} \begin{array}{l} \left(\boldsymbol{\delta }'_{\!\!i}\right)^{T}=\left\{\boldsymbol{\delta }_{i}\times \left[\left(\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i}\right)\times \boldsymbol{\delta }_{i}\right]\right\}^{T}/r_{i}\\[4pt] =-\left[\left(\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i}\right)\times \boldsymbol{\delta }_{i}\right]^{T}\dfrac{\hat{\boldsymbol{\delta }}_{i}}{r_{i}}=-\dfrac{\boldsymbol{{V}}^{T}}{r_{i}}\left(\begin{array}{c} {\hat{\boldsymbol{\delta }}_{i}}^{2}\\ \hat{\boldsymbol{{e}}}_{i}{\hat{\boldsymbol{\delta }}_{i}}^{2} \end{array}\right)\!, \\[15pt] \boldsymbol{\delta }_{i}\left(\boldsymbol{\delta }'_{\!\!i}\right)^{T}=\boldsymbol{\delta }_{i}\left\{-s\left[\left(\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i}\right)\times \boldsymbol{\delta }_{i}\right]\boldsymbol{\delta }_{i}/r_{i}\right\}^{T}\\[4pt] =-\left[\left(\boldsymbol{{v}}+\boldsymbol{\omega }\times \boldsymbol{{e}}_{i}\right)\times \boldsymbol{\delta }_{i}\right]^{T}\dfrac{\boldsymbol{\delta }_{i}{\boldsymbol{\delta }_{i}}^{T}\boldsymbol{{C}}}{r_{i}}=-\boldsymbol{{V}}^{T}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i} \end{array}\right)\dfrac{\left(\boldsymbol{\delta }_{i}{\boldsymbol{\delta }_{i}}^{T}\boldsymbol{{C}}\right)}{r_{i}}, \end{array} \end{equation*}
 \begin{equation*} \begin{array}{l}\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}'_{\!\!\omega i}=\hat{\boldsymbol{\delta }}_{i}\left[\left(\begin{array}{c@{\quad}c} \boldsymbol{{J}}'_{\!\!\omega i1} & \boldsymbol{{J}}'_{\!\!\omega i2} \end{array}\right)-d'_{\!\!i1}\boldsymbol{{J}}_{\omega i}\right]/d_{i1}=\boldsymbol{{V}}^{T}\boldsymbol{{h}},\\[5pt]\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}'_{\!\!\omega i1}=\hat{\boldsymbol{\delta }}_{i}\left(\boldsymbol{{d}}_{i2}\hat{\boldsymbol{\delta }}_{i}^{2}\right)^\prime=\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{d}}'_{\!\!i2}\hat{\boldsymbol{\delta }}_{i}^{2}+\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{d}}_{i2}\left(\hat{\boldsymbol{\delta }}_{i}^{2}\right)^\prime=\boldsymbol{{V}}^{T}\boldsymbol{{h}}_{i1},\\[5pt] \boldsymbol{{h}}_{i1}=-\left(\boldsymbol{{J}}_{\omega i}^{T}\boldsymbol{{R}}_{i1}\boldsymbol{{R}}_{i2}^{T}-\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{{I}} \end{array}\right)\boldsymbol{{R}}_{i2}\boldsymbol{{R}}_{i1}^{T}\right)\left(\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{C}}\right)\hat{\boldsymbol{\delta }}_{i}^{2}\\[6pt]\qquad +\left(\begin{array}{c} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\dfrac{\hat{\boldsymbol{\delta }}_{i}^{2}}{r_{i}}\left\{\left(\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{d}}_{i2}\boldsymbol{{C}}\right)\hat{\boldsymbol{\delta }}_{i}+\left[\left(\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{d}}_{i2}\right)\hat{\boldsymbol{\delta }}_{i}\right]\boldsymbol{{C}}\right\}\!, \\[9pt] \hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}'_{\!\!\omega i2}=\hat{\boldsymbol{\delta }}_{i}\left(d'_{\!\!i1}\boldsymbol{{I}}-\boldsymbol{{d}}_{i2}{\hat{\boldsymbol{{r}}}{'}}_{\!\!i}-\boldsymbol{{d}}'_{\!\!i2}\hat{\boldsymbol{{r}}}_{i}-\boldsymbol{{J}}_{\omega i1}{\hat{\boldsymbol{{e}}}{'}}_{\!\!i}-\boldsymbol{{J}}'_{\!\!\omega i1}\hat{\boldsymbol{{e}}}_{i}\right)=\boldsymbol{{V}}^{T}\boldsymbol{{h}}_{i2},\\[5pt]\boldsymbol{{h}}_{i2}=\left(\begin{array}{c} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)\hat{\boldsymbol{\delta }}_{i}+\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{{I}} \end{array}\right)\boldsymbol{{R}}_{i2}\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i1}\right)\hat{\boldsymbol{\delta }}_{i}\\ \qquad +\left(\begin{array}{c} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left\{\left[\hat{\boldsymbol{\delta }}_{i}s\left(\boldsymbol{{R}}_{i2}\times \boldsymbol{{R}}_{i1}\right)\right]\boldsymbol{{C}}\right\}+\left(\boldsymbol{{J}}_{\omega i}^{T}\boldsymbol{{R}}_{i1}\boldsymbol{{R}}_{i2}^{T}\right)\left(\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{C}}\right)\hat{\boldsymbol{{r}}}_{i}\\[8pt] \qquad -\left(\left(\begin{array}{c} \boldsymbol{0}\\[5pt] \boldsymbol{{I}} \end{array}\right)\boldsymbol{{R}}_{i2}\boldsymbol{{R}}_{i1}^{T}\right)\left(\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{C}}\right)\hat{\boldsymbol{{r}}}_{i}+\left(\begin{array}{c} \boldsymbol{0}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left[\left(\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}_{\omega i1}\right)\boldsymbol{{C}}\right]-\boldsymbol{{h}}_{i1}\hat{\boldsymbol{{e}}}_{i},\\[13pt]\boldsymbol{{h}}= \left. \dfrac{\left(\begin{array}{c@{\quad}c} \boldsymbol{{h}}_{i1} & \boldsymbol{{h}}_{i2} \end{array}\right)}{d_{i1}}-\left[\left(\begin{array}{c} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left(\boldsymbol{{R}}_{i1}\times \boldsymbol{{R}}_{i2}\right)+\left(\begin{array}{c} \boldsymbol{0}\\ \boldsymbol{{I}} \end{array}\right)\boldsymbol{{R}}_{i2}\left(\boldsymbol{{r}}_{i}\cdot \boldsymbol{{R}}_{i1}\right)\right]\dfrac{\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}_{\omega i}}{d_{i1}}\right]\end{array}\end{equation*}
Differentiating v pi (i = 1, 2, 3) in Eq. (A12), a pi is derived using Eqs. (A12) and (A13) as follows:
 \begin{equation} \begin{array}{l}\boldsymbol{{a}}_{pi}=\boldsymbol{{v}}^{\prime}_{\!\!pi}=\boldsymbol{{J}}_{vpi}\boldsymbol{{A}}+ \boldsymbol{{J}}^{\prime}_{\!\!vpi}\boldsymbol{{V}},\boldsymbol{{J}}^{\prime}_{\!\!vpi}=\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{vpi},\\[3pt] \boldsymbol{{J}}^{\prime}_{\!\!vpi}=\left[\left(\begin{array}{c@{\quad}c} \boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T} & - \left(\boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}\right)\hat{\boldsymbol{{e}}}_{i} \end{array}\right)- \left(r_{i}- l_{pi}\right)\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}_{\omega i}\right]\!'\\[10pt] =\left[\left(\begin{array}{c@{\quad}c} \left(\boldsymbol{\delta }^{\prime}_{\!\!i}\boldsymbol{\delta }_{i}^{T}+ \boldsymbol{\delta }_{i}{\boldsymbol{\delta }^{\prime}}_{\!\!i}^{T}\right) & - \left(\boldsymbol{\delta }^{\prime}_{\!\!i}\boldsymbol{\delta }_{i}^{T}+ \boldsymbol{\delta }_{i}{\boldsymbol{\delta }^{\prime}}_{\!\!i}^{T}\right)\hat{\boldsymbol{{e}}}_{i}- \boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}{\hat{\boldsymbol{{e}}}{'}}_{\!\!i} \end{array}\right)\right.\\[7pt] - \left[\left(r_{i}- l_{pi}\right)^\prime\hat{\boldsymbol{\delta }}_{i}+ \left(r_{i}- l_{pi}\right){\hat{\boldsymbol{\delta }}{'}}_{\!\!i}\right]\boldsymbol{{J}}_{\omega i}- \left(r_{i}- l_{pi}\right)\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}^{\prime}_{\!\!\omega i}, \end{array}\end{equation}
 \begin{equation*} \begin{array}{l} \boldsymbol{{H}}_{vpi}\mathit{=}\left(\begin{array}{c@{\quad}c} \boldsymbol{{h}}_{pi1} & \boldsymbol{{h}}_{pi2} \end{array}\right)- \left(r_{i}- l_{pi}\right)\boldsymbol{{h}}\\[4pt] \qquad\quad - \left(\begin{array}{c} \boldsymbol{{I}}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left[\boldsymbol{\delta }_{i}\hat{\boldsymbol{\delta }}_{i}- \left(r_{i}- l_{pi}\right)\dfrac{\hat{\boldsymbol{\delta }}_{i}^{2}}{r_{i}}\boldsymbol{{C}}_{e}\right]\boldsymbol{{J}}_{\omega i},\\[16pt] \boldsymbol{{h}}_{pi1}\mathit{=}- \dfrac{1}{r_{i}}\left\{\left(\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i} \end{array}\right)\boldsymbol{{C}}_{e}\right)\boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}+\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i} \end{array}\right)\left[\left(\boldsymbol{\delta }_{i}\boldsymbol{\delta }_{i}^{T}\right)\boldsymbol{{C}}\right]\right\}\!, \\[10pt] \boldsymbol{{h}}_{pi2}\mathit{=}- \boldsymbol{{h}}_{pi1}\hat{\boldsymbol{{e}}}_{i}+\left(\begin{array}{c} \boldsymbol{0}\\ \hat{\boldsymbol{{e}}}_{i} \end{array}\right)\left[\left(\boldsymbol{\delta }_{1}\boldsymbol{\delta }_{1}^{T}\right)\boldsymbol{{C}}\right] \end{array} \end{equation*}
Differentiating v qi (i = 1, 2, 3) in Eq. (A12), a qi is derived using Eqs. (A12) as follows:
 \begin{equation*} \boldsymbol{{a}}_{qi}=\boldsymbol{{J}}_{vqi}\boldsymbol{{A}}+\boldsymbol{{J}}'_{\!\!qvi}\boldsymbol{{V}},\boldsymbol{{J}}'_{\!\!qvi}=\left(- l_{qi}\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}_{\omega i}\right)^\prime=- l_{qi}\left({\hat{\boldsymbol{\delta }}{'}}_{\!\!i}\boldsymbol{{J}}_{\omega i}+\hat{\boldsymbol{\delta }}_{i}\boldsymbol{{J}}'_{\!\!\omega i}\right)=\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{vqi}, \end{equation*}
 \begin{equation} \boldsymbol{{H}}_{vqi}=\dfrac{l_{qi}}{r_{i}}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{i}^{2}\\ \hat{\boldsymbol{{e}}}_{i}\hat{\boldsymbol{\delta }}_{i}^{2} \end{array}\right)\boldsymbol{{C}}_{e}\boldsymbol{{J}}_{\omega i}- l_{qi}\boldsymbol{{h}} \end{equation}
A.3. Velocity and acceleration of moving links in r 0
Let
 $\boldsymbol{\omega}$
0 and
 $\boldsymbol{\varepsilon}$
0 be the angular velocity and the angular acceleration of r
0 in {B}, respectively. Since the upper end of r
0 is fixed onto m at o and r
0|z is satisfied,
 $\boldsymbol{\omega}$
0 =
 $\boldsymbol{\omega}$
and
 $\boldsymbol{\varepsilon}$
0 =
 $\boldsymbol{\varepsilon}$
are satisfied. r
0 is composed of a piton rod with its mass center p
0 and a cylinder with its mass center q
0. Let r
0 be the distance from O to o. Let l
p0 be the distance from o to p
0. Let l
q0 be the distance from O to q
0. Let
v
g0 and
a
g0 be respectively the translational velocity and the acceleration of the moving link g
0 in r
0 at its mass center in {B}, g = p for the piston rod, g = q for the cylinder. As i = 0, e
i
= 0 are satisfied, the angular velocity and translational velocity kinematics of g
0 are represented as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{\omega }_{0}=\boldsymbol{{J}}_{\omega 0}\boldsymbol{{V}}=\boldsymbol{\omega },\ \boldsymbol{{J}}_{\omega 0}=\left(\begin{array}{c@{\quad}c} \boldsymbol{0} & \boldsymbol{{I}} \end{array}\right),\ \boldsymbol{{J}}'_{\!\!\omega 0}=\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{\omega 0}, \\[5pt] \boldsymbol{\varepsilon }_{0}=\boldsymbol{{J}}_{\omega 0}\boldsymbol{{A}}+\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{\omega 0}\boldsymbol{{V}}=\boldsymbol{{J}}_{\omega 0}\boldsymbol{{A}}=\boldsymbol{\varepsilon },\\[5pt] \boldsymbol{{H}}_{\omega 0}=\boldsymbol{0},\ \boldsymbol{{J}}'_{\!\!\omega 0}=\boldsymbol{0},\ \boldsymbol{{v}}_{p0}=\boldsymbol{{J}}_{vp0}\boldsymbol{{V}},\ \boldsymbol{{v}}_{q0}=\boldsymbol{{J}}_{vq0}\boldsymbol{{V}},\\ [5pt]\boldsymbol{{J}}_{vp0}=\boldsymbol{\delta }_{0}\boldsymbol{\delta }_{0}^{T}\left(\begin{array}{c@{\quad}c} \boldsymbol{{I}} & \boldsymbol{0} \end{array}\right)-\left(r_{0}-l_{p0}\right)\hat{\boldsymbol{\delta }}_{0}\boldsymbol{{J}}_{\omega 0},\ \boldsymbol{{J}}_{vq0}=-l_{q0}\hat{\boldsymbol{\delta }}_{0}\boldsymbol{{J}}_{\omega 0} \end{array} \end{equation}
here,
J
 $_{\omega 0}$
is the 3 × 6 rotational Jacobian matrix of r
0;
H
 $_{\omega 0}$
is the 3 × 6 rotational Hessian matrix of r
0.
The several items
 $ \{\boldsymbol{\delta}'_0, {(\boldsymbol{\delta}'_0)}^T, \boldsymbol{\delta}_0 {(\boldsymbol{\delta}'_0)}^T \} $
for solving
a
g0 are derived from Eqs. (A13) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{\delta }'_{\!\!0}=-\dfrac{\boldsymbol{{V}}^{T}}{r_{0}}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{0}\\ \boldsymbol{0} \end{array}\right)\boldsymbol{{C}}_{e}\boldsymbol{\delta }_{0},\left(\boldsymbol{\delta }'_{\!\!0}\right)^{T}=-\dfrac{\boldsymbol{{V}}^{T}}{r_{0}}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{0}^{2}\\ \boldsymbol{0} \end{array}\right)\!, \\[16pt] \boldsymbol{\delta }_{0}{\boldsymbol{\delta }^{\prime}}_{\!\!0}^{T}=-\dfrac{\boldsymbol{{V}}^{T}}{r_{0}}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{0}\\ \boldsymbol{0} \end{array}\right)\left(\boldsymbol{\delta }_{0}{\boldsymbol{\delta }_{0}}^{T}\boldsymbol{{C}}\right) \end{array} \end{equation}
Differentiating v p0 in Eq. (A16), the formulas for solving a p0 are derived using Eqs. (A16) and (A17) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{a}}_{p0}=\boldsymbol{{J}}_{vp0}\boldsymbol{{A}}+\boldsymbol{{J}}'_{\!\!vp0}\boldsymbol{{V}}=\boldsymbol{{J}}_{vp0}\boldsymbol{{A}}+\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{vp0}\boldsymbol{{V}},\\ [5pt]\boldsymbol{{J}}'_{\!\!vp0}=\left[\boldsymbol{\delta }_{0}\boldsymbol{\delta }_{0}^{T}\left(\begin{array}{c@{\quad}c} \boldsymbol{{I}} & \boldsymbol{0} \end{array}\right)-\left(r_{0}-l_{p0}\right)\hat{\boldsymbol{\delta }}_{0}\boldsymbol{{J}}_{\omega 0}\right]^{\prime}=\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{vp0},\\[16pt] \boldsymbol{{H}}_{vp0}=\left(\begin{array}{c@{\quad}c} -\left(\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{0}\\ \boldsymbol{0} \end{array}\right)\boldsymbol{{C}}_{e}\right)\dfrac{\boldsymbol{\delta }_{0}\boldsymbol{\delta }_{0}^{T}}{r_{0}}-\dfrac{1}{r_{0}}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{0}\\ \boldsymbol{0} \end{array}\right)\left[\left(\boldsymbol{\delta }_{0}{\boldsymbol{\delta }_{0}}^{T}\right)\boldsymbol{{C}}\right] & \boldsymbol{0} \end{array}\right)\\[16pt] \qquad\quad -\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{0}\\ \boldsymbol{0} \end{array}\right)\hat{\boldsymbol{\delta }}_{0}\boldsymbol{{J}}_{\omega 0}+\dfrac{\left(r_{0}-l_{p0}\right)}{r_{0}}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{0}^{2}\\ \boldsymbol{0} \end{array}\right)\boldsymbol{{C}}_{e}\boldsymbol{{J}}_{\omega 0} \end{array} \end{equation}
here, H vp0 is the 6 × 6 translational Hessian matrix of the piston rod as g = p in r 0.
Differentiating v q0 in Eq. (A16), the formulas for solving a q0 are derived using Eqs. (A16) and (A17) as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{a}}_{q0}=\boldsymbol{{J}}_{vq0}\boldsymbol{{A}}+\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{vq0}\boldsymbol{{V}}, \boldsymbol{{H}}_{vq0}=\dfrac{l_{q0}}{r_{0}}\left(\begin{array}{c} \hat{\boldsymbol{\delta }}_{0}^{2}\\ \boldsymbol{0} \end{array}\right)\boldsymbol{{C}}_{e}\boldsymbol{{J}}_{\omega 0},\\ \boldsymbol{{J}}'_{\!\!vq0}=\left(-l_{q0}\hat{\boldsymbol{\delta }}_{0}\boldsymbol{{J}}_{\omega 0}\right)^\prime=-l_{q0}\left[\left(\boldsymbol{\delta }'_{\!\!0}\right)^{T}\boldsymbol{{C}}\right]\boldsymbol{{J}}_{\omega 0}=\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{vq0} \end{array} \end{equation}
here, H vq0 is the 6 × 6 translational Hessian matrix of the cylinder rod in r 0.
The formulas for solving the general velocity V gi and the general acceleration A gi of the moving links g i in r i (i = 0, 1, 2, 3) are represented as follows:
 \begin{equation} \begin{array}{l} \boldsymbol{{V}}_{gi}=\left(\begin{array}{c} \boldsymbol{{v}}_{gi}\\ \boldsymbol{\omega }_{i} \end{array}\right)=\boldsymbol{{J}}_{gi}\boldsymbol{{V}},\ \boldsymbol{{J}}_{gi}=\left(\begin{array}{c} \boldsymbol{{J}}_{vgi}\\ \boldsymbol{{J}}_{\omega i} \end{array}\right)\!, \ \boldsymbol{{J}}'_{\!\!gi}=\boldsymbol{{V}}^{T}\boldsymbol{{H}}_{gi},\\[16pt] \boldsymbol{{A}}_{gi}=\left(\begin{array}{c} \boldsymbol{{a}}_{gi}\\ \boldsymbol{\varepsilon }_{i} \end{array}\right)=\boldsymbol{{J}}_{gi}\boldsymbol{{A}}+ \boldsymbol{{V}}^{T}\boldsymbol{{H}}_{gi}\boldsymbol{{V}},\ \boldsymbol{{H}}_{gi}=\left(\begin{array}{c} \boldsymbol{{H}}_{vgi}\\ \boldsymbol{{H}}_{\omega i} \end{array}\right)\!, \begin{array}{c} i=0,1,2,3;\\ g=p,q \end{array} \end{array} \end{equation}
Appendix B
A logical block of equivalent simulation mechanism of the gripper with three fingers and its simulation mechanism are constructed by Matlab/Simulink/Mechanics, see Fig. B1.
A logical block of equivalent simulation mechanism of the gripper with three fingers (a) and its simulation mechanism (b)

A logical block of parallel wrist is constructed using Matlab/Simulink/Mechanics, see Fig. B2.
A logical block of parallel wrist

A logical block of RPR-type actuation limbs r 1, r 3 are constructed using Matlab/Simulink/Mechanics, see Fig. B3.
Logical block of RPR-type actuation limb r 1.

A logical block of finger is constructed using Matlab/Simulink/Mechanics [Reference Lu, Chang and Lu20], see Fig. B4.
A logical block of finger.

Absolute errors Δx = abs(x-x s ) between the maximum theoretical solutions x and the maximum simulation solutions x s