When the “Occupy Wall Street” movement began in September of 2011, it quickly adopted the slogan “We are the 99%” expressing outrage over the massive inequality in the United States and elsewhere (e.g., Stiglitz Reference Stiglitz2011). The explicit comparison between the income and wealth enjoyed by a tiny minority compared with the vast majority provided the emotional fuel that launched widespread protests in the United States and elsewhere.
In the case of the Occupy movements, economic inequality appeared to trigger widespread collective action on a global scale. Yet, in other cases even more extreme social and economic disparities are sustained over long time periods without protests or rebellions. Political scientists, especially Gurr (Reference Gurr1970), have pointed to psychological mechanisms such as relative deprivation as potential explanations for the occurrence and timing of political protests. According to this view, revolts and rebellions are rooted in the perceived discrepancy between an individual’s standing in society and her aspirations, resulting in anger, discontent, and ultimately protest or violent action (see also Gurney and Tierney Reference Gurney and Tierney1982).
Although these explanations are certainly plausible, they are largely developed in isolation from strategic considerations such as selective incentives (Olson [1965] Reference Olson1971) or community enforcement (Ostrom Reference Ostrom1990) that have dominated the analysis of collective action in the rational choice tradition. In this paper, we analyze the consequences of psychological mechanisms based on social comparisons in the context of strategic interaction as captured by game-theoretic models.
In contrast to classical game theory, however, agents in our model are not fully rational. Rather, in our model, actors adapt via aspiration-based processes: they are more likely to choose an action if it yielded a satisfactory payoff in the preceding period, and less likely otherwise. (Psychologists call this reinforcement learning.) A payoff is satisfactory if it exceeds the agent’s aspiration level. Aspiration levels, however, are not fixed; they are functions of other agents’ payoffs (Bendor, Diermeier and Ting Reference Bendor, Diermeier and Ting2007b; Cui, Zhai and Liu Reference Cui, Zhai and Liu2009). In brief, agents observe the payoffs of others in their reference group, compare their payoff with that reference payoff and then interpret their own payoff as satisfactory or unsatisfactory.Footnote 1 Note that agents do not form explicit expectations about the actions of other players in choosing their own actions; instead, they respond to positive and negative feedback based on social comparisons.Footnote 2
Social psychologists have long argued that social comparisons are a central feature of human life. Following the seminal work of Sherif (Reference Sherif1936) and, especially, Festinger (Reference Festinger1954), a multitude of studies have shown how social comparisons influence judgments (e.g., evaluation of self and others), affect, and even actions. For example, individuals assessed their own health more positively if they compared themselves with others in poorer health (Suls, Marco and Tobin Reference Suls, Marco and Tobin1991), even if they suffered from cancer (see Van der Zee, Buunk and Sanderman Reference Van der Zee, Buunk and Sanderman1998) or severe cardiac problems (Helgeson and Taylor Reference Helgeson and Taylor1993). Similarly, couples expressed more satisfaction with their relationships when they compare themselves with other couples with perceived lower satisfaction. In a recent brain imaging study, Fliessbach et al. (Reference Fliessbach, Weber, Trautner, Dohmen, Sunde, Elger and Falk2007) provided neurophysiological evidence for the importance of social comparison on reward processing in the human brain.
Social comparisons can also have behavioral consequences. Smokers were more likely to quit if they associated themselves with other smokers who were more able to quit (Gerrard et al. Reference Gerrard, Gibbons, Lane and Stock2005). High school students who compared themselves with peers who out-performed them improved their grades more than others who did not (Blanton et al. Reference Blanton, Buunk, Gibbons and Kuyper1999). Individual spending decisions and self-reported happiness depend on relative comparisons of income (Veenhoven Reference Veenhoven1991; Karlsson et al. Reference Karlsson, Dellgran, Klingander and Garling2004; Luttmer Reference Luttmer2005; Clark, Frijters and Shields Reference Clark, Frijters and Shields2008; Caporale et al. Reference Caporale, Georgellis, Tsitsianis and Yin2009). In political domains voters evaluate incumbents based on relative comparisons of economic performance (Kayser and Peress Reference Kayser and Peress2012).
Social structures such as reference groups are conveniently modeled as networks (e.g., Jackson Reference Jackson2008). In the context of social comparisons, for example, individual i may compare herself with individual j by tracking j’s payoff. Social comparisons may not be symmetric. That is, i may track j, but j may pay no attention to i. To capture different strengths of influence, we will use influence matrices that assign different weights to different comparisons. Although social influence networks are often exogenous, they may also change over time either randomly or in response to received payoffs (e.g., Lazer et al. Reference Lazer, Rubineau, Chetkovich, Katz and Neblo2010). In our model, we allow for influence structures that change over time.
Our model examines the impact of such comparisons on collective choice contexts. We represent these interactions as non-cooperative games. We proceed in three steps. First, we establish some general characteristics of adaptation under social comparisons. These results hold for any strategic interaction modeled as a repeated normal form game. They identify network properties of social comparison that determine whether stable outcomes require equal payoffs for all players. Thus, they are especially relevant to a classical problem in political sociology: the stability of inequality (e.g., Runciman Reference Runciman1966).
Second, we apply these results to two important types of collective action problems: public goods and resource allocation. This allows us to probe what stabilizes hierarchies. Our main results establish that the stability of unequal distributions depends on a key feature of social comparisons. If agents compare themselves only with agents with the same or lower payoffs, inequality can be stable. If, however, they “look up”—their aspirations are driven by the perception of people who are doing better than they are—then inequality is unstable.
Finally, we use computational methods to do two things: check the robustness of the analytical model and “smooth it out,” that is, allow us to examine the degree of instability of different outcomes (and hence of different systems). Fortunately, these two tasks complement each other: once we have done the latter, doing the former turns out to be easy. Proceeding in this way, we find that our main results (properly understood) are robust: inequality tends to destabilize outcomes.
The Model
Basic Concepts and Notation
Throughout the paper we assume infinitely repeated normal form games, with fixed stage games and deterministic payoffs. Let t denote discrete time periods and i denote actors (i=1, … , n), with n finite. Each player i has m i >1 actions, where m i is finite. Player i’s generic action is denoted α i . An outcome o corresponds to an element in the associated normal form payoff matrix. We write α(o) to denote the action profile that generates outcome o and α i (o) to denote i’s action within that profile.
A player’s probability of playing action α i at t is denoted p i,t (α i ). Similarly, p i,t is i’s probability distribution over all actions at t. Let π i,t (o) denote i’s payoff, given outcome o. Aspiration levels are called a i,t . We assume that there is an aspiration level for each possible payoff level, that is, for each i, t, and o there exists some a i,t such that a i,t =π i,t (o). For convenience, we will drop time subscripts when the meaning is clear.
Propensity and Aspiration Adjustment
Players’ propensities are governed by two similar mechanisms. At each period, every player i becomes more likely to choose an action if it was coded as successful in the previous period. A success for i occurs when her payoff exceeds her aspiration level. Analogously, i reduces her likelihood of choosing any action coded as a failure. Observe that these rules are compatible with a wide range of functional forms.
A1 (positive feedback): if i used action α i in t and if π i,t ≥a i,t then p i,t+1(α i )≥p i,t (α i ); this conclusion holds strictly if p i,t (α i )<1 and π i,t >a i,t .
A2 (negative feedback): if i used action α i in t and if π i,t <a i,t then p i,t+1(α i )≤p i,t (α i ); this conclusion holds strictly if p i,t (α i )>0.
The heart of aspiration adjustment is that aspirations respond to experience (payoffs). In this model, agent i’s aspiration in period t+1 is a weighted average of his current payoff and those of some of the other players. We call the latter i’s reference group. If player j is in i’s reference group then we will say that i tracks j, as shorthand for “i tracks j’s payoff.” We call this a process of social comparison. We also assume that a i,t+1 is always influenced by i’s current aspiration, a i,t .
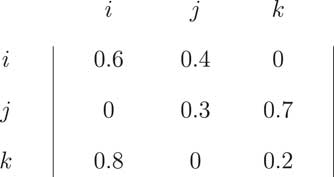
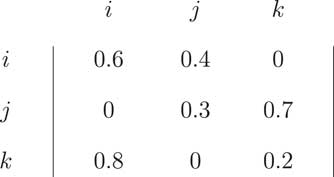
It is convenient to represent a specific pattern of aspiration adjustment by an n by n matrix, called Λ, where element (i, j) reports the impact that j’s payoff has on i’s aspiration adjustment. (Following Jackson (Reference Jackson2008, 230), we refer to Λ as a social influence matrix). For example, suppose there are three players, i, j, and k. Then a social influence matrix for this group could be as shown in Figure 1.
3×3 influence matrix Note: a “ring” influence matrix: i tracks j but not k, j tracks k but not i, and k tracks i but not j.
Social influence matrices are usually assumed to be exogenously fixed. Such models are more tractable than are those in which actors have some discretion about social comparisons. However, there is evidence that some people make choices about at least part of their reference group (Taylor and Lobel Reference Taylor and Lobel1989; Buunk et al. Reference Bush and Mosteller1990; Collins Reference Collins1996). Further, it is plausible that there is some random fluctuation in how much people track others. Our model allows for both of these possibilities. (It requires neither.) It does so by allowing a group to have many possible social influence matrices, which accommodates random fluctuations, and by allowing the probability that a specific matrix is evoked in a specific period to depend on the payoffs players received in that period, thus permitting a certain endogeneity of reference groups.
Let us unpack this. Let L≡{Λ1, … , Λ r } denote a group’s set of possible influence matrices, with r≥1. (For the sake of tractability we assume that r is finite). Where the meaning is clear, we use Λ to denote a generic member of L. The element Λ i,j q denotes i’s weight on j’s payoff under Λ q . Player i’s remaining weight is placed on his previous period’s aspiration. Though not an element of the matrix Λ q , this weight is denoted λ i q . The probability that matrix Λ q is evoked in period t is denoted ρ q (o). In effect, we are allowing players to observe each other’s realized payoffs but not their actions. Hence, if two different action vectors produce the same vector of payoffs then they generate the same probability distribution over L.
We can see how this setup allows for endogenous reference groups by re-examining the above three-person example. Suppose player j is ambitious, in the sense of only tracking players who receive higher payoffs than he does in any given period. Suppose in outcome o 1 the payoffs are π i (o 1)>π j (o 1)>π k (o 1), whereas in outcome o 2, they are π i (o 2)<π j (o 2)<π k (o 2). If o 1 happens in t, then the probability that j tracks k in t is zero, whereas if o 2 occurs then the chance that j tracks i in t would be zero. Formally, this would be represented by the probability distribution of ρ q (⋅), which conditions on the realized payoff vector. If this distribution is the same for all possible payoff vectors, then we recover the simple case of exogenously fixed social influence. (Note, however, that even this simple case allows for random fluctuations in who tracks whom).
These social influence matrices and their associated probabilities may reflect some interdependence among players’ reference groups. For example, suppose i and j form a tight subgroup, so Λ i,j >0 and Λ j,i >0 in every Λ in L. Hence, their tracking of k may not be independent: roughly speaking Pr(Λ i,j >0 and Λ j,i >0) could exceed Pr(Λ i,j >0)⋅Pr(Λ j,i >0). (Indeed, it may be that for every Λ∈L player k is either in the reference groups of both i and j or she is in neither reference group; the mixed cases never occur).
A3 summarizes the assumptions about aspiration adjustment.
A3 (aspiration adjustment):
-
(i) There are r≥1 n×n social influence matrices, labeled Λ q (1≤q≤r). The probabilities ρ q (o) of selecting Λ q are fixed and independent over time but may depend on o, the realized vector of payoffs.
-
(ii) For any realized social influence matrix Λ q , the weights
 $\Lambda _{{i,\,\,j}}^{q} $
are non-negative and on each row i (i=1, … , n) sum to
$$1{\minus}\lambda _{i}^{q} $$
, where
$\lambda _{i}^{q} \in (0,1)$
is the weight on a
i,t
in Λ
q
.
-
(iii) For any realized social influence matrix Λ q ,
$$a_{{i,t{\plus}1}} =\lambda _{i}^{q} a_{{i,t}} {\plus}\mathop{\sum}\nolimits_{j\,=\,1}^n {{\rm \Lambda }_{{i,\,\,j}}^{q} \pi _{{j,t}} } $$
.


Note that A3 allows for the possibility that some players adjust their aspirations in a purely individualistic way. This occurs for player i when
 $\lambda _{i}^{q} {\plus}\Lambda _{{i,i}}^{q} =1$
for all Λ
q
∈L.
It is worth emphasizing that players in our model are not imitating each other’s actions. Instead, what social comparisons directly impact is a cognitive variable: aspiration levels. Thus, our model combines key features of two lines of network research that have remained mostly disjoint: models in which players imitate actions (Jackson Reference Jackson2008, Chapter 9) and those which focus on the diffusion of opinions, information, and other cognitive variables (Jackson Reference Jackson2008, Chapter 8). The former are often “behaviorist”: they may not represent any cognitive variables at all. The latter are often purely cognitive: the agents may not take any actions; everything—for example, opinion change—happens inside their heads. In our model, a cognitive variable (aspirations) and an associated adaptive rule drive behavior. Actions in turn generate payoffs that impact the cognitive variable, and around it goes.
Note that our model defines a stochastic process, with states that are sets of action propensities and aspirations. The best understood kinds of stochastic processes are Markovian—tomorrow’s probability distribution over the possible states depends only on today’s state and the transition rules—with stationary (time-homogeneous) transition rules. Fortunately, however, few of our results require these properties.
Of course, imposing special structure usually boosts a model’s predictive power, so in the penultimate section (and occasionally elsewhere), we will exploit the added power conferred by assuming that the stochastic process is both Markovian and stationary. Indeed, we will soon see that thinking about these special types of stochastic processes helps to give us intuitions about what kinds of outcomes we should expect to see and which we should not.
First, however, we must examine the primitives of our process—action propensities and aspirations—and the implications of our basic axioms, A1–A3. Intuitively, if the process settles down on some of these states then it probably also settles down on their observable products: actions and outcomes. Hence, it makes sense to look for states with self-replicating properties. This idea is expressed in Macy and Flache’s (Reference Macy and Flache2002) notion of a self-reinforcing equilibrium (SRE) with endogenous aspirations, where both aspirations and propensities are fixed points. Here, we focus on a generalization of their solution concept. In this generalization, the propensities must be self-replicating. Specific aspiration values need not, however, replicate themselves, that is, they do not need to be fixed points. (This is useful because reference groups and hence aspirations can change over time). Instead, we require only that there exists a set of aspirations that (a) is absorbing—once aspirations enter the set they never leave it—and (b) as long as aspirations stay in that set then propensities replicate the required specific values. (Of course, a singleton set can satisfy these properties). Formally,
Definition 1:
A SRE is a vector of propensities (p
i,t
)
i
and a compact set of aspirations
 $${\cal A}_{i} $$
satisfying
 $$a_{{i,t}} \in {\cal A}_{i} $$
for each i, where for all i, α
i
, and t′>t:
-
(i)
$$p_{{i,t'}} (\alpha _{i} )=p_{{i,t}} (\alpha _{i} )$$
, -
(ii)
$$a_{{i,t'}} \in {\cal A}_{i} $$
.


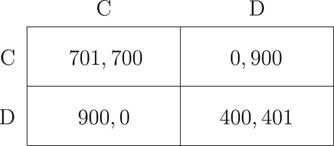
SREs do not exist in all games, even for stationary Markovian processes. Consider the example in Figure 2. In this example, no outcome is stable in the above sense if both players track each other. However, the absence of stable outcomes does not mean that the model makes no prediction. It means only that the process does not in the limit get absorbed into an outcome. Instead, the process will exhibit more complicated dynamics: individual sample paths never settle down.Footnote 3 (As we will see in the penultimate section, if the sample paths produced by players interacting in the game of Figure 2 are produced by a stationary Markov process then under plausible conditions the process will produce a stable distribution of outcomes).
No stable outcome
General Results
We now investigate how the structure of social comparison determines whether unequal outcomes are stable. The topic of stable hierarchies is, of course, a venerable one in political sociology, going back to Marx and de Tocqueville.
We show that there are two distinct forces underlying social comparison that link stability and equality. One is the sheer availability of information about how other people are doing. In many contemporary societies, it can be hard to avoid social comparisons: modern media regularly put them before us. This factor is exogenous in our model. The other force is partly endogenous reference groups, produced by the proclivities of people tantalized by those who are doing better than they are. We take these up in turn.
Exogenously Dense Social Comparisons
Our first set of general results turn on a key network property concerning the density of reference groups among a set of players. This property is probabilistic: it allows for different social comparisons (different Λ’s) to hold at various dates. In order to explain this concept clearly, it is helpful to first introduce a simpler, deterministic notion that is a special case of ours.
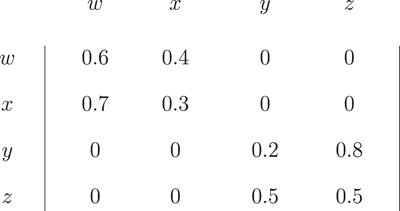
Let us reconsider the social influence matrix of Figure 1. This is a ring structure: i tracks j, j tracks k, and k tracks i. We will call this a strongly connected network or structure.Footnote 4 As the term suggests, a strongly connected system cannot be broken up into self-contained subsystems. For an example of a reference group structure that is decomposable, consider the social influence matrix of Figure 3.
4×4 influence matrix Note: a decomposable influence matrix: w and x track only each other, and y and z track only each other.
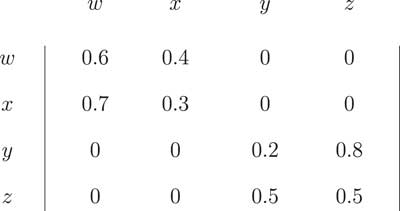
This matrix represents a community that in terms of aspiration adjustment can be broken down into two subsets: {w, x} and {y, z}. Nobody in either subset tracks anyone in the other subset. In contrast, it is impossible to decompose the three actors of Figure 1 into self-contained subsets: all three are linked. These examples are especially simple because implicitly we have been assuming that L, the set of feasible social influence matrices, is a singleton, consisting only of the matrix of Figure 1 or of Figure 3, respectively. Given this, we can say that the social comparisons of Figure 1 form a deterministic network. As the model of the present paper allows for randomness in reference groups—different social influence matrices can occur in different periods—we use a probabilistic notion of relatedness.
Informally, a set of players are probabilistically strongly connected if, for every partition of the set into two disjoint, non-empty subsets, there’s a chance—not necessarily a certainty—that at least one person in each subset tracks someone in the other subset. This idea is formalized below.
Definition 2:
Set N is (probabilistically) strongly connected if, for every J⊂N, where J≠∅ and J≠N, there exists some j∈J and i∈N\J and some Λ
q
∈L such that
 $\Lambda _{{j,i}}^{q} \,\gt\, 0$
and there exists some i′∈N\J and j′∈J and some Λ
q′∈L such that
 $\Lambda _{{i'j'}}^{{q'}}\, \gt \,0$
.
If a network of social comparisons is deterministically strongly connected then of course it must be probabilistically so as well. (It is easy to check, for instance, that the matrix of Figure 1 satisfies Definition 2.) However, the converse does not hold: the players could form a probabilistically strongly connected system even if no feasible social influence matrix satisfies Definition 2 by itself. For example, suppose that there are three feasible Λ’s for some three-person group. In Λ1, the only social comparison is that i tracks j; in Λ2, only j tracks k; in Λ3, just k tracks i. Although any particular reference group structure is decomposable, the set of players is probabilistically strongly connected.
Henceforth, we will simply say that a set of players is strongly connected, as shorthand for saying that it is probabilistically strongly connected in the sense of Definition 2.
Our first result shows that if reference groups are dense enough to create a strongly connected community then outcomes with heterogeneous payoffs will not be tolerated: they are unstable. (The proofs of Theorem 1 and of most of the other results are in the appendix.)
Theorem 1: If the set of players is strongly connected then an outcome is supported by a SRE if and only if that outcome gives all players the same payoff.
Theorem 1 yields the following corollary. (The proof, being straightforward, is omitted.) Suppose, we restrict attention to aspiration-based adaptive rules that are Markovian and stationary. In this context, Theorem 1 implies that if payoffs are heterogeneous in every outcome then no outcome is stable. This corollary tells what will not happen but not what will. What, then, should we expect to occur in such circumstances? We will return to this question in penultimate section.
Strongly connected social comparison networks produce a drive toward equality for a simple but powerful reason: such systems are dense enough to ensure that some people on the bottom of a hierarchy track some people who are doing better than they are. To see this in a stark setting, consider a community divided into two groups: haves and have nots—A’s and B’s, respectively. All A’s get the same payoff, π A ; all B’s get π B <π A . Suppose B’s tracked only each other. Then in the steady state their aspirations would equal π B , whence they would be content with their lot. Therefore, this outcome can be stabilized by some self-enforcing equilibrium. (It does not matter whom A’s track: they will be satisfied in any network of social comparisons.) However, if B’s track only each other then the system is not strongly connected: if the community is partitioned into A’s and B’s then with probability one nobody in the latter tracks anyone in the former, which violates Definition 2. If the system were strongly connected then at least one B would sometimes track an A. However, if that happened then that B’s aspiration would exceed π B —and she would be dissatisfied with her action. This would destabilize inequality.
The logic of this simple example holds generally.
Proposition 1: An outcome with unequal payoffs is supported by a self-enforcing equilibrium only if there is no Λ such that an agent with the minimum payoff tracks any agent receiving more than the minimum payoff, that is, only if nobody at the bottom tracks anyone higher.
Strong connectedness ensures that the condition described by Proposition 1 cannot hold. Moreover, as this condition of nobody at the bottom tracking anyone higher is necessary for inequality, strong connectedness is sufficient for equality.
We next explore inequality, when Proposition 1’s condition does hold.
Partially Decomposable Communities
We call a group of players closed if nobody in the group tracks anyone outside it, under any matrix in L.
Theorem 2: If the players can be partitioned into k disjoint non-empty groups, A 1, … , A k (1<k<n) such that each group is strongly connected and l of the groups (1≤l≤k), A 1, … , A l , are closed, then the following conclusions hold.
-
(i) An outcome can be supported by a SRE only if all payoffs in group A q are the same, for all q=1, … , l.
-
(ii) If all k groups are closed (i.e., l=k) then homogeneous within-group payoffs is also sufficient for the conclusion of (i).
The exogenous reference group structure of Theorem 2 permits the existence of stable payoff inequalities.Footnote 5 We will explore the impact of endogenous reference groups in the next section.
Endogenous Reference Groups
Now we analyze social comparisons that are influenced by realized outcomes. Players, knowing these outcomes, can compare themselves to people who are doing better than they or to those doing worse.
In the following results,
 $\bar{\pi }(o)$
denotes the highest payoff that any player gets in outcome o, whereas
 $$\underline {\pi }(o)$$
is the lowest.
Definition 3:
Social comparisons are based on looking upwards if the following condition holds for all outcomes: if
 $$\pi _{i} (o)\,\lt \,\bar{\pi }(o)$$
for player i in outcome o, then given o player i tracks j only if π
j
(o)>π
i
(o).
Theorem 3: If social comparisons are based on looking upwards and for every i and every o there is a Λ
q
(o)∈L such that
 $$\lambda _{i}^{q} (o){\plus}\Lambda _{{_{i} _{{,i}} }}^{q} (o)\lt {\rm 1}$$
then an outcome is supported by a SRE if and only if that outcome gives all players the same payoff.
As Runciman and other political sociologists have argued, looking up creates a drive toward equality.Footnote 6 Note that social comparisons may be based on looking upwards yet not produce a strongly connected network. For example, suppose that we are investigating the stability of outcome o, which yields different payoffs for all agents. (For convenience, number the players so that π 1(o)>… >π n (o)). Assume that actors 2 through n look up; specifically, they track only player 1. Obviously, these social comparisons destabilize this outcome: the aspiration level of everyone other than player 1 is a weighted average of his own payoff and the top value, π 1(o), so dissatisfaction is rampant. However, this network is not strongly connected. (To see this, partition it into the subsets of {1} and {2, … , n}. Nobody in the first subset tracks anyone in the second one (i.e., player 1 tracks no one); hence, Definition 2’s criterion is not satisfied.Footnote 7 ) This shows that ambitious social comparisons and strong connectivity are different causes of the same effect.
In contrast to the restlessness produced by looking up, looking down or sideways produces contentment with the status quo (Runciman Reference Runciman1966).Footnote 8 Hence, these kinds of social comparisons stabilize inequality.
Definition 4: Social comparisons are based on looking downwards or sideways if the following condition holds for all outcomes: given outcome o player i tracks j only if π i (o)≥π j (o).
Theorem 4: If social comparisons are based on looking downwards or sideways then any outcome, no matter how unequal the payoffs, is supported by some SRE.
If some people in the community are ambitious—they look up—whereas others prefer the self-enhancement generated by looking down or sideways, then stability requires appeasing the ambitious.
Corollary 1:
If the set of players is divided into two subsets, those who look up and those who look down or sideways, and
 $\lambda _{i}^{q} {\plus}\Lambda _{{_{i} _{{,i}} }}^{q} \lt {\rm 1}$
for all ambitious players in all Λ
q
, then an outcome o is supported by a SRE if and only if all the ambitious agents get
 $$\bar{\pi }(o)$$
, the maximal payoff anyone gets in o.
The corollary points out the stabilizing force of raising the payoffs of ambitious community members, or cooptation. If inequality is to be stable, those on top must figure out how to coopt those who are (1) less well off and (2) ambitious.
Another way of stating the necessity condition in Corollary 1 is as follows. Suppose a player would look up if someone’s payoff exceeded his. Then he would be disgruntled: his aspiration would exceed his payoff. So that outcome would be unstable, even if all the other players were content with their lot. Note that these results go well beyond relative deprivation theory (Gurr Reference Gurr1970), which predicts that social comparisons lead to the formation of social movements and rebellions, but does not predict that the outcomes of such activities will eventually lead to less inequality. Our model implies not only protest activity, but less unequal social outcomes.
To further explore these issues, we investigate two specific collective choice problems: the production of public goods and the allocation of resources.
Collective Action Problems and Inequality
Viable communities must solve two vital collective action problems. First, they must produce some public goods. This usually includes security (Tilly Reference Tilly1992); it often includes the protection of a commons or some other resource (Ostrom Reference Ostrom1990). Second, they must figure out some way to allocate resources without too much violence. Either process can produce inequality. Some people may shirk in the production of collective goods, thus exploiting those who work hard. In resource allocation, some people may behave more aggressively than others and thereby grab bigger slices of the pie. Hence, both of these critical processes can be conflictual: those who are more pro-social may wind up with less value than those who are less pro-social.
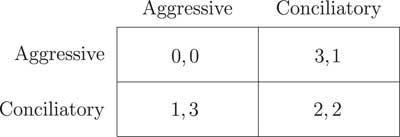
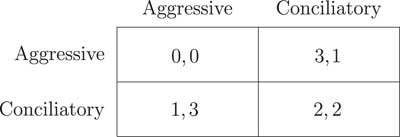
We represent these possibilities by a large class of games. Although the games are symmetric in the standard sense—everyone has the same set of actions and reversing two players’ actions reverses their payoffs—this class of games is defined by their asymmetric outcomes. Roughly speaking, the defining property is this: if player i’s action is more pro-social than player j’s, then the latter’s payoff exceeds the former’s.Footnote 9 (As the game is symmetric, if the players use the same action then their payoffs are equal). For example, the infamous game of Chicken belongs to this class. As Figure 4 shows, if player 1 is aggressive, whereas player 2 is conciliatory, then the former’s payoff exceeds the latter’s. (Indeed, player 1 gets the game’s maximal payoff in this circumstance.)
Chicken game
We will give a precise definition of this class of games below. First, we must provide some notation and assumptions. The common action set is {α 1, … , α m }, with m>1. Without loss of generality, the actions are labeled so that lower-numbered actions are more pro-social than higher-numbered actions. For example, cooperation in the standard binary-choice Prisoner’s Dilemma would be α 1; defection would be α 2.
Definition 5: A symmetric one-shot game is called conflictual if α i (o)=α r , α j (o)=α s , and r<s for any outcome o and any players i and j, then π i (o)<π j (o).
Note that in resource allocation contexts, aggressive agents are generally being more active than their less aggressive brethren, whereas in public good games shirking often entails passivity. Despite this difference, in both situations it is clear which actions are pro-social and which are not.
We model a community of n players who are playing a conflictual game in every period. The game may involve providing a public good or resource allocation or any other situation that satisfies Definition 5. Consider a community with k>1 groups. Can these groups form a stable hierarchy? The following pair of results address this question. Note that Corollary 2 follows from Theorem 3: given the key property of conflictual games—if two actors take different actions then the more pro-social one gets a lower payoff—everybody will be satisfied with an outcome only if they use the same action.
Corollary 2:
Suppose that social comparisons are based on looking upwards and
 $\lambda _{i}^{q} {\plus}\Lambda _{{_{} _{{i,i}} }}^{q} \lt {\rm 1}$
for all i and all q. If the stage game is conflictual then an outcome can be supported by a SRE, if and only if everyone takes the same action (and hence gets the same payoff).
The following result follows from Theorem 4. What we call higher status groups are those that get higher payoffs than lower status ones. Thus, the groups form a hierarchy.
Corollary 3: Suppose that social comparisons are based on looking downwards or sideways. If the stage game is conflictual and actors have at least as many actions as there are groups, then there exists an SRE in which the groups form a hierarchy: (1) actions within a group are homogeneous and (2) actions across groups are heterogeneous, with higher status groups behaving in a less pro-social way than lower status ones.
Finally, once again we see a connection between cooptation and stable inequality.
Corollary 4: Suppose the hypotheses of Corollary 1 hold. If the stage game is conflictual then an outcome is supported by a SRE only if (i) all ambitious agents behave homogeneously and (ii) nobody behaves in a less pro-social way than the ambitious agents.
Part (ii) of this result implies that the ambitious agents get the maximal payoff,
 $\bar{\pi }(o)$
.
Our analysis shows that social reference structures where agents look downwards and sideways can sustain unequal social hierarchies. Members of each social stratum do equally well, but across strata behavior differs: groups of higher status take advantage of lower ones by behaving less pro-socially, either by contributing less to public goods or by grabbing more resources. Social hierarchies thus become self-sustaining. Lower status people end up with less but, perhaps because of their lower status, do not compare themselves with higher status individuals. These restrictions to downward and sideways comparisons maintain unequal allocations in equilibrium.
Robustness and Degrees of Instability: A Computational Model
Thus far we have used analytical methods to investigate the relation between inequality and instability. These approaches are powerful but they exact a price: to keep a model tractable, assumptions often must be stated crisply—for example, payoffs are either exactly equal or they are not. Further, the stability concept of self-reproducing equilibria is also crisp: either an outcome is an SRE or it is not. Together, these two dichotomies yield a conclusion—unequal payoffs are unstable (Theorems 1 and 3)—that is very sharp but perhaps unrealistically so. Inequality is a matter of degree. Some payoffs, though not precisely equal, are almost so; others are wildly divergent. As the current controversy over income inequality in the United States indicates, the degree of inequality matters empirically. Similarly, the intuitive hypothesis is that outcomes in the real world exhibit degrees of stability: they are not either perfectly stable or completely unstable.
Hence, it makes sense to examine the relation between inequality and instability under a more nuanced set of assumptions. In this section, we will investigate whether an increase in payoff inequality makes an outcome less stable, a continuous analog to the analytical model’s dichotomous conclusion that unequal payoffs are unstable.
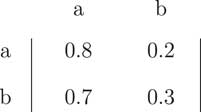
Fortunately, there are standard methods for studying degrees of stability. Probably the best-known approach is to construct a model which has an ergodic stochastic process: (1) there is a unique invariant probability distribution over the state space and (2) the process converges to that unique distribution from any initial vector of probabilities over the states. In the present context, ergodicity would ensure that there is an invariant distribution over actions and outcomes. This in turn automatically provides a stability metric: an outcome’s stability is measured by a continuous variable, its limiting probability, which reflects how long the process will dwell there in the long run. For example, consider the (stationary) Markov chain in Figure 5.
Two-state probability transition matrix
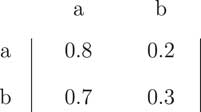
Neither state is absorbing, so neither is perfectly stable. Clearly, however, state a is more stable than b: the process is likely to leave the latter but not the former. This difference is reflected in the states’ limiting probabilities: a’s is
 ${7 \over 9}$
; b’s, only
 ${2 \over 9}$
.
There are several ways to ensure that our process is ergodic for a large class of n-person games. A convenient standard approach is to introduce shocks to action propensities: at any date an agent might move to a propensity vector that is totally mixed over his set of actions. Thus, with a possibly small probability, an agent does not do what she intends to do. The shocks to action propensities are independent across players and i.i.d. for a given agent. (For technical reasons one also must ensure that the process is aperiodic, i.e., does not mechanically alternate between states. This is easily accomplished by introducing a small amount of inertia into the adjustment processes, which is what we do here.)
As it is difficult to solve this model analytically, that is, to generate closed-form results, we mostly use computational methods. (At the end of this section, we examine a special case that is tractable enough to allow us to return to analytical methods.) The computational model, which we describe below, can address robustness questions by generating numerical output regarding the limiting distribution.Footnote 10
To reduce computing time, we study the simplest possible strategic contexts, 2×2 games. For the adjustment of action propensities, we use the standard Bush–Mosteller rule, a cornerstone of many models of learning and adaptive behavior.Footnote 11 Adjustment in this rule is a linear function of the amount of available propensity. For example, suppose that an agent has two actions, cooperate (C) or defect (D), and she tries C in t and it yields a satisfactory payoff (i.e., positive feedback). Then
 $$p_{{C,t{\plus}1}} =p_{{C,t}} {\plus}\theta (1{\minus}p_{{C,t}} ),$$
where θ, a constant in (0,1], is the speed of adjustment. An analogous equation holds for negative feedback.
The agents update their aspirations each round according to a simple weighted average rule. For example, for agent 1 the rule is as follows:
 $$a_{{1,t{\plus}1}} =(0.7)a_{{1,t}} {\plus}(0.3){{\pi _{{1,t}} {\plus}\pi _{{2,t}} } \over 2}.$$
Agent 2’s rule is analogous. (Note that because the agents always track each other they form a strongly connected system, in the sense of Definition 2.)
In each round the following sequence of events occurs:
-
1. Agents choose an action according to their action propensity vector.
-
2. Payoffs are realized according to the payoff matrix of the stage game.
-
3. Agents compare their payoff with their aspiration and, if not inertial, adjust action propensities accordingly. Inertia occurs with probability 0.01 in each round. They update their action propensities according to the Bush–Mosteller heuristic (1) with θ=0.1. With probability 0.01, an agent’s propensity vector is subject to an additive normally distributed tremble with mean zero and standard deviation of 0.01.Footnote 12
-
4. Agents update their aspiration levels according to (2). With probability 0.01, an agent is inertial and does not adjust aspirations.
The simulation program is implemented in the R programming language and is available in an online supplementary appendix. The program simulates 1000 independent plays of a two agent, normal form repeated game. For each set of 1000 plays, the program generates data on the frequency of each outcome. Thus, outcomes that occur more often over the long run are considered more stable. We present results for 100, 1000, 10,000, and 20,000 rounds of play to show that the mean frequencies of each outcome have settled into their long-run values.
To get things going, we assume that agents choose actions in round 1 by flipping an unbiased coin. Aspirations initially equal 1.5, which is the average of the four payoffs used in the simulations.
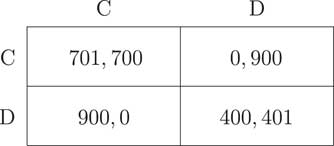
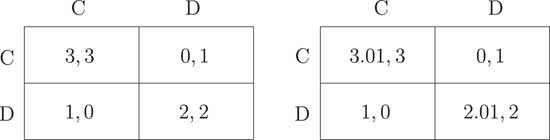
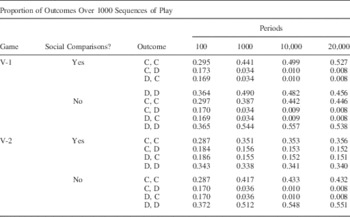
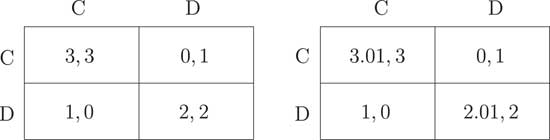
We can now analyze the model’s robustness regarding payoff symmetry. First, consider games V-1 and V-2, as illustrated in Figure 6: the former is a perfectly symmetric instance of Stag Hunt; the latter, a slightly asymmetric version of the same basic game. The output for both games, with and without social comparisons, is displayed in Table 1. Two features of the case where players track each other are worth noting. First, the stability ranking of the outcomes is the same in the two games. In particular, (C, C) and (D, D) are each more likely in the limit than is either (D, C) or (C, D). Thus, the introduction of slight payoff asymmetries in game V-2 does not affect this fundamental property. The main diagonal outcomes in V-2 are nearly symmetric, whereas the payoffs of (D, C) and (C, D) are quite different. This matters.
Games V-1 and V-2 (Stag Hunt) Note: left: game V-1, which is a standard Stag Hunt. Right: game V-2, which perturbs the payoffs of V-1.
Simulation Results for Games V-1 and V-2

Second, (C, C) and (D, D) are noticeably less stable in game V-2 than they are in V-1.Footnote 13 This is a continuous version of the analytical model’s main theme: when the network of social comparisons is strongly connected, as it is in these simulations, increased inequality reduces stability.Footnote 14 In comparison, when neither player tracks the other, the slight increase in payoff asymmetry in the main diagonal outcomes has no effect.
Readers might wonder, however, whether our explanation of the first property is correct. Although it is true that the main diagonal outcomes in game V-2 are more equal than are the off-diagonal outcomes, the former also Pareto dominate the latter. Moreover, as aspiration-based adaptation tends to revisit alternatives that yield good payoffs (those that satisfy aspirations) and to avoid bad ones (those that do not), one would expect Pareto domination alone to matter. The reason is straightforward. If payoffs {a, b} Pareto dominate {c, d} and the latter are satisfactory then the former must also be, but the opposite does not hold: {a, b} could be satisfactory, yet {c, d} not. In short, all else equal, Pareto superiority should enhance stability. This could be a confounding hypothesis.
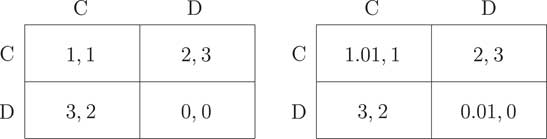
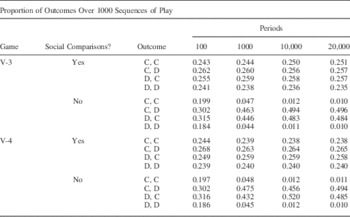
Game V-3, shown in Figure 7, allows us to test this guess by pulling apart payoff symmetry and Pareto optimality. In this game, the outcomes with equal payoffs are Pareto dominated by those with asymmetric payoffs. Analogously to game V-2, game V-4 perturbs these payoffs slightly.
Games V-3 and V-4 Note: left: game V-3, which has symmetric payoff outcomes that are Pareto dominated. Right: game V-4, which perturbs the payoffs of V-3.
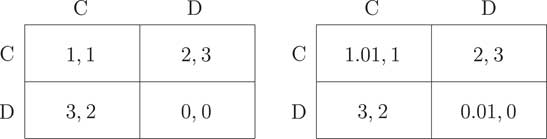
Table 2 illustrates the results for V-3 and V-4 both with and without social comparisons. In game V-3, the two forces are opposed: the destabilizing force of inequality and social comparisons pushes the process toward (C, C) and (D, D), but Pareto superiority pulls it toward the other two outcomes. In the parametric version at hand, game V-3, these two forces almost cancel each other out: the four outcomes are nearly equally likely in the long run.
Simulation Results for Games V-3 and V-4

In this context, making the main diagonal outcomes slightly asymmetric (game V-4) has almost no effect: what makes these outcomes somewhat unstable is that they are strongly Pareto dominated by (D, C) and (C, D), which is unaffected by the introduction of slight payoff asymmetries in (C, C) and (D, D).
What does have a strong effect is the presence or absence of social comparison. When players do not track each other in game V-3, the asymmetric but Pareto-optimal outcomes now take the lion’s share of the limiting distribution. This shows that it was indeed their inequality that prevented them from being more stable than the symmetrically bad outcomes of (C, C) and (D, D) in V-3, with its strongly connected network of social comparisons.
Isolating the Effects of Inequality
As we have seen, the preceding simulations were somewhat complicated to analyze because of the intertwined effects of inequality and Pareto dominance. In this last subsection, we focus exclusively on inequality by examining constant-sum games. In such games, all outcomes are necessarily Pareto optimal. Hence, we can now study the effects of variations in inequality in splendid isolation.
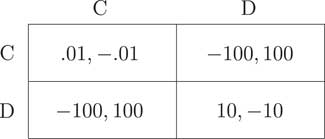
Consider, for example, the constant-sum game depicted in Figure 8. Whereas there is enormous inequality in two outcomes, (C, D) and (D, C), payoffs are nearly equal in the other two outcomes. If Theorem 1 is robust then in the long run (C, C) and (D, D) should occur more frequently than do the off-diagonal outcomes.
Game V-5 (constant sum)
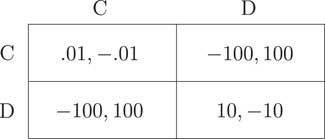
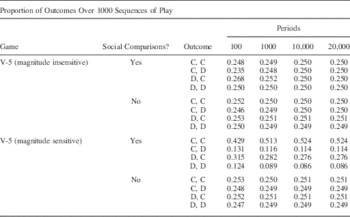
However, a simulation of game V-5 reveals that the outcomes are essentially equally likely in the long run (Table 3).Footnote 15 This would be unsurprising if social comparisons were disabled but as the table indicates, this occurs when social comparisons are enabled. Indeed, the output displayed in Table 3 is based on a strong degree of social comparison: when adjusting aspirations each player puts as much weight on his partner’s payoff as his own. Despite this, big variations in inequality seem to have no effect: outcomes with nearly equal payoffs are no more likely in the long run than those with huge inequalities.
Simulation Results for Game V-5

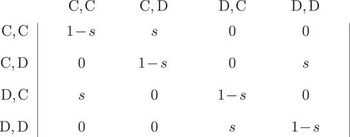
This anomaly is not confined to a computational model; it reappears in an analytical one. When players put equal weights on each other’s payoffs and the game is zero sum, it is easy to see that both aspirations must converge to zero. This enables us to study the process’s long-run patterns analytically, if the propensity adjustment rule is sufficiently simple. For example, in the bang-bang Bush–Mosteller rule, where propensities adjust completely to zero or one, the only non-transient propensities are zero and one. As the long run depends only on non-transient states, we can analyze this case by examining a reduced form in which the only propensity values are zero and one. Further, because we know that the only non-transient aspiration level is the game’s constant sum, the probability transition matrix that yields the (unique) invariant distribution for the non-transient states can be represented as shown in Figure 9, where s denotes the probability that the agent switches to a new action (i.e., puts a propensity of one on a new action).
Transition matrix for non-transient states in constant-sum game with bang-bang Bush–Mosteller rule

This matrix immediately implies that in the unique limiting distribution all outcomes are equally likely. The simulation got it right.
Why does intuition fail here? Why are the nearly equal outcomes not much more likely in the long run than the grossly unequal ones? We believe that this is an artifact of a discontinuity in the propensity adjustment rule. In the standard Bush–Mosteller rule that drives these simulations, propensity change responds only to the sign of feedback; it is insensitive to magnitudes, for example, how big is negative feedback. This is why the transition probabilities in Figure 9 are the same. Our axioms of propensity adjustment, A1 and A2, do allow for this magnitude insensitivity; they do not, however, require it. Accordingly, although Theorem 1 and the other analytical results hold for magnitude-insensitive rules such as Bush–Mosteller, they also hold for rules that respond continuously to feedback. Agents using a magnitude-sensitive rule would, for example, react more strongly to a big disappointment—payoffs far below aspirations—than to a small one. Moreover, we conjecture that the anomaly would disappear if the simulation were based on such a rule.
We can test the above reasoning by making propensity adjustment continuous in the difference between aspirations and payoffs. Here, we assume this in a simple way, by endogenizing the inertia parameter that governs propensity adjustment. Thus, a player is inertial—does not change action propensities—with probability
 ${\rm 1}\,{\minus}\,\psi $
, which decreases in the difference between aspirations and payoffs. Assumption A4 expresses the idea formally.
A4 (magnitude-sensitive adjustment): for every agent i the probability of adjustment,
 $$\psi \left( {\left| {a_{{i,t}} \,{\minus}\,\pi _{{i,t}} } \right|} \right)$$
, is a strictly increasing and continuous function, with
 $\psi (0)=0$
.
It suffices to make the probability of inertia depend continuously on the magnitude of the discrepancy between aspirations and payoffs; the rest of the propensity adjustment mechanism can have discontinuities, as does, for example, the bang-bang Bush–Mosteller. As this adaptive rule is so tractable, we continue to use it here. Now, however, it is activated with probability ψ and inactive with the complementary probability.Footnote 16
If we re-run game V-5 with a magnitude-sensitive propensity adjustment rule, we see that here intuition is confirmed: the most nearly equal outcome is indeed much more likely in the long run than highly unequal ones (bottom half of Table 3). As conjectured, the surprising result for the magnitude-insensitive case shown in the top half of Table 3, which seemed to indicate that Theorem 1 is not robust, was an artifact of a discontinuity in the simulation’s propensity adjustment rule.
The logic underlying this conclusion does not depend on the particular parameter values used in the magnitude-sensitive simulation. It generalizes to a large class of constant-sum 2×2 games, as we now show.Footnote 17
In what follows, b denotes the sum of the players’ payoffs in a constant-sum game and
 $$\tilde{p}(o)$$
is the limiting probability of outcome o.
Remark 1:
Consider any constant-sum 2×2 game in which π
1
(o)≠π
2
(o) for all outcomes o. If
 $$a_{i,t{\plus}{\rm 1}} _{{}} =\lambda _{i} a_{{i,t}} {\plus}({\rm 1}{\minus}\lambda _{i} ){{\pi _{i,t} {{}} {\plus}\pi _{j,t} _{{}} } \over {\rm 2}}$$
for
 $$i=1,{\rm }2$$
, propensities adjust by a bang-bang Bush–Mosteller that satisfies A4, and neither player has a strategy that yields more than
 $ {b \over 2}$
independently of the other player’s strategy then the following properties hold.
-
(i) The process is ergodic and the limiting distribution is over four states. The action propensities of these four states are defined by the four possible combinations of zero–one propensities and hence can be described by the four action pairs: (C, C), (C, D), (D, C), and (D, D).
-
(ii)
$$\tilde{p}(o_{r} )\,\gt\, \tilde{p}(o_{s} )$$
if and only if |π
1(o
r
)−π
2(o
r
)|<|π
1(o
s
)−π
2(o
s
)|. -
(iii)
$${{\partial \tilde{p}(o_{r} )} \over {\partial \,\mid\,\pi _{1} (o_{r} ){\minus}\pi _{2} (o_{r} )\,\mid\,}}\,\lt\, 0$$
.


Part (ii) implies that the more equal outcomes are more likely in the long run than are less equal ones. Part (iii), a comparative static, says that if an outcome becomes more equal then it happens more often in the limit.
Remark 1 is confined to 2×2 games. Our last result examines the issue of robustness in a more general setting. Proposition 2 uses the following notion of a “small” degree of inequality. We will say that outcome o is in an ɛ-neighborhood of complete equality if there exists an ɛ>0 such that
 $\left| {{b \over n}{\minus}\pi _{i} (o)\mid\leq \varepsilon } \right|$
for i=1, … , n.
As we are now examining n-person games, we cannot state simple conditions that suffice to ensure ergodicity as we could for 2×2 games. Fortunately, however, this does not matter, because the next result establishes that the effect of near equality is close to that of complete equality for any invariant distribution that the process might reach. (Moreover, part (i) of the proposition shows that it must reach some invariant distribution.)
Proposition 2:
Consider any constant-sum game with n>1 players, where every player has finitely many actions and in every outcome o there are players i and j such that π
i
(o)≠π
j
(o). If
 $$a_{{i,t{\plus}1}} =\lambda _{i} a_{{i,t}} {\plus}(1{\minus}\lambda _{i} ){{\mathop{\sum}\nolimits_{j=1}^n {\pi _{{j,t}} } } \over n}$$
for i=1, … , n and action propensities adjust by a bang-bang Bush–Mosteller that satisfies A4 then the following hold.
-
(i) The process converges to an invariant distribution.
-
(ii) If the process has converged to an invariant distribution with exactly one non-transient outcome,
$$o^{{\rm {\asterisk}}} $$
, that is in an ɛ-neighborhood of complete equality then
$$\tilde{p}(o^{{\rm {\asterisk}}} )$$
is close to 1 for ɛ “small.”


Proposition 2 shows that when the issue is exclusively how the pie is cut—its size being constant—and players make social comparisons then the degree of inequality matters, provided that propensity adjustment is continuous. This indicates that Theorem 1 and the other analytical results are robust in a restricted but still important sense: when people are more likely to respond to big disappointments than to small ones, complete equality is inessential.
Conclusion
Public outrage based on a experience of relative deprivation has often been suggested as an explanation for political protest. Yet, in other cases highly unequal societies are stable without widespread protests. In this paper, we propose an explanation for these disparate findings using a framework that combines adaptive processes based on social comparisons with strategic interactions analyzed by non-cooperative game theory. Our framework provides a rich set of results. The first set of findings pertains to general n-person contexts. We showed that as long as people track the payoffs of some other players, the set of stable outcomes is tightly restricted: under very general assumptions people must receive the same payoff in an outcome supported by a self-reinforcing equilibrium. Loosely speaking, social comparison generates uniformity in payoffs among strongly connected players. Inequality is not tolerated. If communities are partially decomposable, however, payoff inequalities shaped by the reference group structure can endure. What matters at a deeper level is whether people with low payoffs compare themselves with those with higher ones. If agents “look up” then inequality is unstable. Computational simulations establish the robustness of the basic intuitions of these analytical results.
The second set of findings showed that similar effects occur in collective action situations. If agents do not look up, then stable hierarchies of inequality can exist. Actions within a group are homogenous, but across status groups actions are heterogenous, with higher status groups acting less cooperatively than lower status groups. Thus, we can show the existence of durable hierarchies of inequality where some groups contribute, whereas others free ride on the contributions of the contributing groups. This shows how a socio-psychological property (“who is in my reference group?”) generates socio-political inequality. Intuitively, the source of unequal hierarchies is a failure of imagination: one does not compare one’s own payoff with those of people in other strata. In turn, a shift in social reference groups, either owing to social changes or better access to media, may upset established hierarchies, as individuals now compare themselves with others that are relatively better off, thus triggering a sense of dissatisfaction that may ultimately lead to political unrest and other forms of collective action.
Our results also shed some light on the impact of social media on social movements and revolts as recently witnessed in the “Arab Spring” (Eltantawy and Wiest Reference Eltantawy and Wiest2011). Many commentators have focused on how social media have allowed political activists and opposition groups to organize more quickly. Our results suggest that new media may also change social reference groups. Once people of lower socio-economic status compare their lot with that enjoyed by the better off, unequal payoffs can no longer be sustained.
Supplementary Material
To view supplementary material for this article, please visit http://dx.doi.org/10.1017/psrm.2015.47
Appendix
Proof of Theorem 1.
Sufficiency. Consider an outcome o in which everyone gets the same payoff, π(o). The candidate pure SRE (i.e., one in which everyone plays pure strategies) is one in which player i plays α i (o) with probability one and in which a i,t =π(o) for all i.
As aspirations equal π(o), everyone is satisfied in t, whence by A1 player i continues to play α i (o) with probability one, for all i.
Further, because everyone is getting the same payoff, by A3 everyone is getting a weighted average of π(o) for any realized Λ. Hence a i,t+1=a i,t .
Thus, the propensity and aspiration vectors of period t are reproduced in t+1. QED.
Necessity. The proof is by contradiction. Suppose that an outcome o* is supported by a pure SRE (i.e., one in which everyone plays pure strategies) but in o* there are at least two people who get different payoffs. That is, there exists an SRE such that
 $${\rm for}\,{\rm all}\,i\,{\rm and}\,t:p_{{i,t}} (\alpha _{i} (o^{{\rm {\asterisk}}} ))=1\,{\rm and}\,a_{{i,t}} \in {\cal A}_{i} ,$$
where
 $${\cal A}_{i} $$
has the properties stipulated by Definition 1, and there exist some distinct i and j such that π
i
(o*)≠π
j
(o*).
As there are at least two players, i and j, who get different payoffs in o*, we can partition N into two non-empty subsets, A and B, such that everyone in A gets the same payoff and everyone in B gets a higher one. (Note that the payoff to players in A is not necessarily the minimal payoff in o*; it is simply less than the payoffs of any of the B players.)
Now consider some i∈A, and suppose that we are trying to stabilize the vector of pure propensities that generates o* and the associated sets of aspirations at some date t. (Recall that because |L|≥1, social comparisons may continually change, whence so may aspirations, even in an SRE.)
As the group is probabilistically strongly connected there must be at least one player in A, say i, at least one player in B, say j, and some Λ
q
∈L such that
 $$\Lambda _{{i,j}}^{q} \,\gt \,0$$
.
We consider three cases.
Case 1: a i,t >π i (o*).
As A2 requires that the action propensity change, whereas the definition of an SRE requires that it remain fixed, in this case we are done immediately.
Case 2: a i,t =π i (o*).
As player i tracks j∈B in at least one Λ, that is, in Λ q , and because ρ q >0, Pr(i tracks nobody in B in t)<1. Hence, a i,t is not absorbing; further, in every period the process can transition to Case 1 with a probability that is bounded away from zero uniformly in t. Therefore, the condition that defines Case 2 cannot be part of an SRE.
Case 3: a i,t <π i (o*).
As here a
i,t
<π
i
(o*) and because a
i,t+1 is a weighted average of a
i,t
, π
i
(o*), and other payoffs (associated with o*) which, because i∈A, must all weakly exceed π
i
(o*), it follows immediately that a
i,t+1>a
i,t
. Hence, no set of aspirations
 $$(\underline {a},\bar{a})$$
, where
 $\bar{a}\,\lt \,\pi _{i} $
(o*), is absorbing. Further, because the set of social influence matrices is fixed and each one is realized with a probability that is bounded away from zero uniformly in t, the second Borel–Cantelli lemma implies that the probability that a
i,t
stays below π
i
(o*) goes to zero as t→∞. Further, as i must be tracking players whose payoffs strictly exceed his, eventually the process must transition to Case 1, whereupon the argument pertaining to that case is activated. QED.
In the proof of Proposition 1 and thereafter we follow the convention of using “with positive probability” (abbreviated by “wpp”) as a shorter way of saying “with strictly positive probability.”
Proof of Proposition 1.
The proof is by contradiction. Suppose outcome o, which yields unequal payoffs, is supported by an SRE, yet there is some player, say i, who gets the minimum payoff and who wpp tracks j, whose payoff exceeds i’s. Then for any social influence matrix for which Λ i,j (o)>0, a i,t >π i . However, then by A2, the axiom of negative feedback, i’s propensity to play α i (o) must decrease. Hence, the assumption that o is supported by an SRE must be false. QED.
Proof of Theorem 2.
-
(i) We check to see whether outcome o′, in which A r -payoffs are heterogeneous, can be supported by an SRE. As A r is sealed off from the other groups, regarding aspirational dynamics we can treat it as a free-standing set of players. Hence, Theorem 1 can be applied. So the answer is negative: outcome o′ cannot be supported by an SRE.
-
(ii) Select an arbitrary group, A r . We check to see whether a certain outcome o, which gives everyone in A r the same payoff, π Ar (o), can be supported by an SRE. (Given that A r was selected arbitrarily, if this works for A r then it will work generally.) Suppose in some period o occurs. We construct vectors of aspirations and propensities that will self-replicate, in the sense of Definition 1. First, let a i,t ≤π A r (o) for all i∈A r . Second, let Pr(α i (o))=1. As i tracks only other people in A r and as in t everyone in A r gets the same payoff from o, a i,t+1=λ i a i,t +(1−λ i )π A r (o). Hence, a i,t+1≤π A r (o), so the players continue to be satisfied by o. Moreover, by simple algebra, all their aspirations continue to be less than or equal to π(o). By induction these properties continue to hold indefinitely, satisfying the definition of a self-replicating equilibrium. QED.
Proof of Theorem 3.
Sufficiency. If everyone gets the same payoff then any convex combination of payoffs (i.e., any combination of Λ i,j ’s) is also the same; call this π. Consider one of these outcomes; call it o. Consider any start in which Pr(α i (o))=1 and a i,0≤π for all i. Then everyone is satisfied in o so by A1 all propensities continue, in t=2, to equal one on the appropriate action. Further, by A3 all aspirations continue to be less than or equal to π in t=2. By induction these properties continue to hold indefinitely, whence o is an SRE. QED.
Necessity. Consider an outcome o (without loss of generality in the public good game) in which payoffs are heterogeneous. Hence, there must be at least two players, say i and j, such that π i (o)<π j (o). As aspirations are formed by looking up, i tracks only players who get more than π i (o). Moreover, because λ i +Λ i,i <1, i must track someone wpp. Hence, wpp a i is a convex combination of i’s payoff and something greater than that, whence a i >π i (o). In such an event, i is dissatisfied, and by A2 reduces her propensity to play α i (o). So o is unstable. QED.
Proof of Theorem 4.
Consider an arbitrary player i. At any date t, either i tracks someone else or she does not. If she does not then a i,t =π i,t . If she does, then she tracks someone who gets a payoff that is equal to or less than π i,t . In this case, a i,t ≤π i,t . In either case she is satisfied with the outcome, o; hence by A1 she will not reduce the propensity to play α i (o). Therefore, the state in which i plays α i (o) with probability one and in which a i =π i (o), for i=1, … , n, is stable. QED.
Proof of Corollary 1.
Sufficiency. Consider an outcome o in which the ambitious players get the maximal payoff,
 $$\bar \pi (o)$$
. As nobody’s payoff exceeds theirs, they are satisfied no matter whom they track. Moreover, as unambitious players look down or sideways, the proof of Theorem 4 holds for this subset. Hence, everyone is satisfied in o, so by the usual construction o is an SRE. QED.
Necessity. Consider an outcome o in which some ambitious player, say i, is not getting the maximal payoff. As λ i +Λ i,i <1, wpp i tracks someone else. Moreover, as i only looks up, anyone who is tracked by i, say j, must satisfy π i (o)<π j (o). Hence a i (o)>π i (o). Thus, i is dissatisfied, which destabilizes o. QED.
Proof of Corollary 2.
As conflictual games are symmetric, if everyone takes the same action (in say the public goods game) then they all get the same payoff. Then Theorem 3 can be applied. QED.
Proof of Corollary 3.
As the game is conflictual, hence symmetric, all players have the same action set. Therefore, m i =m for all i. Further, it is given that m≥k, where k is the number of groups. (To avoid triviality we assume that k>1.) Thus, without loss of generality we can label the groups and the actions so that in outcome o players in group j use action α j , where j=1, … , k. Then Theorem 4, which holds for arbitrary outcomes, can be applied. QED.
Proof of Corollary 4.
As the result states that both (i) and (ii) are necessary, we take them up separately. First, we assume that (ii) holds and analyze (i)’s necessity. As Corollary 1 holds here, we know that all ambitious players must get
 $$\bar \pi (o)$$
, the maximum payoff that anyone receives in outcome o. Further, both stage games are conflictual, and Definition 5 states that if two players use different actions then they get different payoffs. As all ambitious players are getting the same payoff, they must be using the same action. Hence, they are behaving homogeneously.
Now we investigate (ii)’s necessity, given that (i) holds. Suppose that i behaves in a more pro-social way than j does in outcome o. By Definition 5, π
i
(o)<π
j
(o). However, then π
i
(o)<
 $$\bar \pi (o)$$
, so by Corollary 1 outcome o is unstable. QED.
Proof of Remark 1.
The following lemma is essential.
Lemma 1: Consider any constant-sum game with n>1 players, where every player has finitely many actions. If
 $$a_{{i,t{\plus}1}} =\lambda _{i} a_{{i,t}} {\plus}(1{\minus}\lambda _{i} ){{\sum_{j=1}^n \,\pi _{{j,t}} } \over n}$$
for i=1, … , n then a
i,t
→b/n as t→∞, for all i.
Proof. Given that
 $$a_{{i,t{\plus}1}} =\lambda _{i} a_{{i,t}} {\plus}(1{\minus}\lambda _{i} ){{\sum_{j=1}^n \,\pi _{{j,t}} } \over n}$$
, by substitution
 $$a_{{i,t{\plus}1}} =\lambda _{i} [\lambda _{i} a_{{i,t{\minus}1}} {\plus}$$
 $$(1{\minus}\lambda _{i} ){{\sum_{j=1}^n \,\pi _{{j,t}} } \over n}]{\plus}(1{\minus}\lambda _{i} ){{\sum_{j=1}^n \,\pi _{{j,t}} } \over n}=(\lambda _{i} )^{2} a_{{i,t{\minus}1}} {\plus}\lambda _{i} (1{\minus}\lambda _{i} ){{\sum_{j=1}^n \,\pi _{{j,t}} } \over n}{\plus}$$
 $$(1{\minus}\lambda _{i} ){{\sum_{j=1}^n \,\pi _{{j,t}} } \over n}$$
. Iterating the substitution, we get
 $$a_{{i,t{\plus}1}} =(\lambda _{i} )^{{t{\plus}1}} a_{{i,0}} {\plus}[(\lambda _{i} )^{t} {\plus}\: \cdots \:\:{\plus}1](1{\minus}\lambda _{i} ){{\sum_{j=1}^n \,\pi _{{j,t}} } \over n}$$
. As λ
i
∈(0,1), (λ
i
)
t+1 goes to zero as t→∞. Therefore, a
i,0’s impact on a
i,t+1 approaches zero as t increases. Moreover, as lim
t→∞
(λ
i
)
t
+ ⋯ +1=1/(1−λ
i
), it follows that a
i,t+1 converges to b/n as t→∞. QED.
For n=2, this specializes to a i,t converging to b/2. With this in hand, we can return to the main proof.
-
(i) First, we establish ergodicity. Observe that the probability transition matrices P 1,P 2, ... (which govern the evolution of action propensities and aspirations) are non-stationary because they depend on ψ i,t , which is a function of |a i,t −π i,t |, which in turn depends on i’s aspiration, and a i,t is changing over time. Thus, given that each player uses the bang-bang Bush–Mosteller to adjust propensities, this is a non-stationary Markov chain. Note that the row entries in any P t depend only on the sign of a i,t −π i,t and the magnitude of ψ i,t .
As Lemma 1 implies that a
i,t
is converging to
 $ {b \over 2}$
as t→∞, it follows that ψ
i,t
→ψ
i
(|(
 $ {b \over 2}$
−π
i,t
|) as t→∞ for
 $$i=1,{\rm }2$$
. Hence, the sequence of probability transition matrices is itself converging to a stationary P
∞. Therefore, by Lemma 2 in Anily and Federgruen (Reference Anily and Federgruen1987, 869), if a non-stationary Markov chain satisfies P
t
→P
∞ and P
∞ is ergodic then the non-stationary Markov chain is itself ergodic: it has a unique invariant distribution over its state space and it must converge to that vector of probabilities from any initial distribution.
Thus far, however, we know only that the sequence of P
t
’s converges to some stationary P
∞; we do not yet know whether P
∞ is ergodic. Hence, we must show that, given the assumptions of Remark 1, P
∞ does in fact represent an ergodic process. To do this, note first that because the game is constant sum,
 $\pi _{i,t} _{{}} \gt {b \over 2}$
if and only if
 $\pi _{j,t} \gt {b \over 2}$
. Thus, as π
i
(o)≠π
j
(o) in all four outcomes of this 2×2 game, exactly one player is dissatisfied in every outcome, given aspirations of
 ${b \over 2}$
. Therefore, the dynamics of the process can be represented by the following schematic matrix.
 $$\eqalignno{ & \matrix{ {\matrix{ {} & \,\hskip2.5pc {\rm \ C \hskip -16pt} & {} & \hskip 20pt {\rm D} \cr } } & {} & {} \cr } \cr & \matrix{ {\rm C} \hskip2pc \cr {} \cr {\rm D} \hskip2pc \cr {} \cr } \left| {\matrix{ {{\plus},\,{\minus}} & {{\minus},\,{\plus}} \cr \to & \downarrow \cr {{\minus},\,{\plus}} & {{\plus},\,{\minus}} \cr \uparrow & \leftarrow \cr } } \right| $$
At this point, the assumption that neither player has a strategy that guarantees satisfaction for
 $a_{i,t} _{{}} \gt {b \over 2}$
is useful. It is easy to see that this condition implies that each player is satisfied in exactly two outcomes. (If, e.g., player 1 were satisfied in three outcomes then she must have a strategy that ensures a satisfactory payoff for her regardless of player 2’s action.) Given this restriction, it follows that there are only two possibilities. Stated from the perspective of player 1, they are (1) player 1 is satisfied by (C, C) and (D, D) or (2) she is satisfied by (C, D) and (D, C). In the other four cases either action C or action D is unconditionally satisfying for player 1 or an action is unconditionally satisfying for player 2.
In possibility (1), transitions in the schematic matrix move clockwise; in (2), counter-clockwise. In either case, the process can reach any of the four action combinations from any of the others. Hence, the states of P ∞ communicate. Further, as ψ(⋅) is strictly increasing in the disparity between aspirations and payoffs, it follows that the probability of inertia (a dissatisfied player not changing his propensities) is strictly positive in every outcome. This ensures aperiodicity. Hence P ∞ is, in fact, ergodic. As we have seen, the limiting distribution is over all four states, which are described as the four action combinations, that is, result (ii)(a) holds. Thus P ∞ is as follows. (Without loss of generality this matrix is based on possibility (1): (C, C) and (D, D) are satisfying for player 1. The logic for the other matrix is identical.)
 $$\eqalignno{ & \matrix{ {\matrix{ {} & {\matrix{ {} & {} & {} & \hskip 20pt {{\rm C,}\,\,{\rm C}} & {} & {} & {} & {} & {} & \hskip 20pt {{\rm C,}\,{\rm D}} & {} & {} \cr } } & {} & {\matrix{ {} & {} & \hskip0.8pc {{\rm D,}\,{\rm C}} & {} & {} & {} & {} & {} \cr } } \cr } } & \hskip 14pt {{\rm D,}\,{\rm D}} & {} \cr } \cr & \matrix{ {{\rm C,}\,{\rm C}} \cr {{\rm C},\,{\rm D}} \cr {{\rm D,}\,{\rm C}} \cr {{\rm D},\,{\rm D}} \cr } \left| {\matrix{ {1{\minus}\psi (\mid{b \over 2}{\minus}\pi _{2} (C,C)\mid)} & {\psi (\mid{b \over 2}{\minus}\pi _{2} (C,C)\mid)} & 0 & 0 \cr 0 & {1{\minus}\psi (\mid{b \over 2}{\minus}\pi _{1} (C,D)\mid)} & 0 & {\psi (\mid{b \over 2}{\minus}\pi _{1} (C,D)\mid)} \cr {\psi (\,\mid\,{b \over 2}{\minus}\pi _{1} (D,C)\mid)} & 0 & {1{\minus}\psi (\mid{b \over 2}{\minus}\pi _{1} (D,C)\mid)} & 0 \cr 0 & 0 & {\psi (\mid{b \over 2}{\minus}\pi _{2} (D,D)\mid)} & {1{\minus}\psi (\mid{b \over 2}{\minus}\pi _{2} (D,D)\mid)} \cr } } \right| $$
Given this matrix, a bit of algebra reveals that
 $${{\tilde{p}({\rm state}\,i)} \over {\tilde{p}({\rm state}\,j)}}$$
equals the inverse of their exit probabilities; for example,
 $${{\tilde{p}(C,C)} \over {\tilde{p}(C,D)}}={{\psi _{{C,D}} } \over {\psi _{{C,C}} }}$$
. Thus, the states’ limiting probabilities are ordered inversely to their associated dissatisfaction probabilities, which establishes (ii).
Further, because the ratio of state i’s limiting probability against any other state’s limiting probability is decreasing in ψ
i
, it follows that
 $$\tilde{p}({\rm state}\,i)$$
is decreasing in ψ
i
, which establishes (iii). QED.
Proof of Proposition 2.
-
(i) The first step in proving that the process must converge to some invariant distribution is to note that because the stage game is constant sum and aspirations adjust via
$$a_{{i,t{\plus}1}} =\lambda _{i} a_{{i,t}} {\plus}(1{\minus}\lambda _{i} ){{\sum_{j=1}^n \,\pi _{{j,t}} } \over n}$$
, a straightforward extension of the two-player result of Remark 1 to this n-player setting yields the fact that a
i,t
converges to
${b \over n}$
as t→∞, for all i. This in turn implies that the sequence of probability transition matrices is converging to a stationary P
∞. As this stationary matrix governs a finite-state Markov chain, it must have at least one invariant distribution. Finally, convergence is ensured because A4 implies that there must be inertia in propensity adjustment, which means that the process is aperiodic. QED. -
(ii) Either P ∞ yields a unique invariant distribution or multiple ones. If there is only one then the states’ limiting probabilities can be computed via P ∞. As these limiting probabilities are continuous in the matrix’s transition probabilities and because o* would be absorbing if all its payoffs were exactly the same, the result follows. If there are multiple invariant distributions then each one must be over a closed class of states, so in effect there are multiple Markov chains that can be analyzed independently: the limiting probabilities for a given closed class of states can be calculated by the corresponding submatrix of transition probabilities, and the continuity property holds as before. QED.