1 Introduction
This paper continues the rigorous study (initiated in Kuznetsov Reference Kuznetsov2011) of the coupled time-harmonic motion of a freely floating rigid body and an inviscid, incompressible, heavy fluid, say water; see also Kuznetsov & Motygin (Reference Kuznetsov and Motygin2011, Reference Kuznetsov and Motygin2012, Reference Kuznetsov and Motygin2015) and Kuznetsov (Reference Kuznetsov2015). We consider infinitely deep water in irrotational motion, bounded from above by a free surface unbounded in all horizontal directions, but unlike the cited papers dealing with the open surface, we assume here that it is totally covered with brash ice. The latter is of importance in many cases; in particular, it complicates shipping around ports in the Arctic and affects offshore structures in the Polar Sea.
The World Meteorological Organization defines brash ice as ‘accumulations of floating ice made up of fragments not more than two meters across; the wreckage of other forms of ice’ (see, for example, the online Encyclopedia of Earth at http://www.eoearth.org/view/article/150762/). This definition literally repeats what is written in Starosolszky (Reference Starosolszky1977) published under the auspices of the International Association for Hydraulic Research. In particular, a slushy mixture of ice and snow is a kind of brash ice which is characteristic of the initial phase of ice formation before it freezes solid; see figure 1 in Hariprasad (Reference Hariprasad, Singh, Singh and Haritashya2011) (it is also available online at http://www.dreamstime.com/abstract-brash-ice-image1851031). The only forces acting on this kind of brash ice are those due to gravity and the pressure of the water from below. This is indeed what we understand by brash ice in this paper. On the other hand, there exists thick brash ice that has more complicated mechanical properties considered, for example, by Mellor (Reference Mellor1980).
In our considerations, the body is supposed to be an infinitely long cylinder which allows us to consider two-dimensional modes orthogonal to the cylinder’s generators. We also assume that the body is surface-piercing and unaffected by all external forces (for example due to constraints on its motion) except for gravity. The motion of the whole system is supposed to be of small amplitude near equilibrium, and so the linear model developed by John (Reference John1949) is used to describe the coupled motion of water and body. His model includes a boundary value problem coupled with a system of algebraic equations, and both involve the frequency of time-harmonic oscillations as the spectral parameter. However, the Steklov-type boundary condition on the free surface must be amended to take into account the presence of brash ice covering the water. A condition used here to describe brash ice was proposed by Peters (Reference Peters1950). According to his model, brash ice is considered as an infinitely thin mat whose particles do not interact. It should be noted that instead of the motion of a mat some authors speak of waves at an inertial surface (see Rhodes-Robinson Reference Rhodes-Robinson1984, Mandal & Kundu Reference Mandal and Kundu1986 and references cited therein) or of the dynamics of flotation liquid (see Gabov & Sveshnikov Reference Gabov and Sveshnikov1991, where one finds the derivation of the corresponding nonlinear time-dependent boundary condition and its linearization).
A notable property of the boundary condition introduced by Peters is that not for all values of angular frequency do time-harmonic progressive gravity waves of small amplitude exist even in the absence of bodies. There is a bound for frequency above which waves cannot propagate. This happens when the infinitesimal layer of brash ice is too ‘heavy’, which is in contrast to the fact that for a sufficiently ‘light’ layer waves propagate, as in the familiar case of the open free surface. These two possibilities were discovered by Peters (Reference Peters1950) in his investigations of waves on an open free surface incident upon an adjoining surface covered by brash ice.
Our aim is to show that results which are, in some sense, similar to those obtained by Peters hold for the system under consideration provided the energy of motion is finite. First, we consider the case when brash ice is ‘light’ for a given value of frequency. Applying the so-called semi-inverse procedure (it is presented in § 4.1), we construct a family of motionless two-dimensional bodies each trapping a time-harmonic mode; that is, the water covered by brash ice and the body oscillate at the same prescribed frequency, whereas the energy of water and ice motion is finite. We recall that a trapped mode in two and three dimensions describes a free oscillation of a system that has finite energy; see Linton & McIver (Reference Linton and McIver2001, p. 17). This should be distinguished from edge waves and waves trapped around an array of cylinders.
It should be mentioned that the same semi-inverse procedure was used by Kuznetsov (Reference Kuznetsov2011) for obtaining two-dimensional trapping bodies that are motionless in the open water. However, there is an essential distinction between the case of open water and water covered by brash ice, namely no restriction was imposed on the trapping frequencies in the former case. On the contrary, trapping frequencies, like propagating waves considered by Peters, are bounded by a constant characterising how ‘heavy’ the brash ice is and this bound is essential in the latter case. Indeed, our second result shows that if a solution of the problem is supposed to have finite energy and the frequency exceeds a certain bound, then this solution is trivial. Generally, this bound is larger than the constant mentioned above, but these bounds may coincide for some bodies. It is also essential that the last result is valid for all bodies irrespective of their shape, whereas some restrictions must be imposed on the body’s geometry in all uniqueness theorems for fixed as well as freely floating bodies. The first condition guaranteeing uniqueness for surface-piercing bodies was introduced by John (Reference John1950); see Kuznetsov, Maz’ya & Vainberg (Reference Kuznetsov, Maz’ya and Vainberg2002) for other geometric conditions in the case of fixed bodies and Kuznetsov (Reference Kuznetsov2015) for a discussion how uniqueness theorems for freely floating bodies are distinguished from those for fixed ones.
2 Statement of the problem
Let the Cartesian coordinate system
 $(x,y)$
in a plane orthogonal to the generators of a freely floating infinitely long cylinder be chosen so that the
 $y$
-axis is directed upwards, whereas the mean free surface of the water intersects this plane along the
 $x$
-axis, and the cross-section
 $W$
of the water domain is a subset of
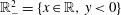 $\mathbb{R}_{-}^{2}=\{x\in \mathbb{R},\,y<0\}$
. Let
 $\widehat{B}$
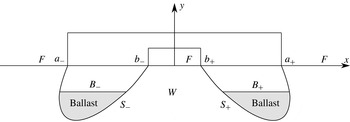
denote the bounded two-dimensional domain whose closure is the cross-section of a floating cylinder in its equilibrium position (see figure 1).
A definition sketch of the cylinder’s cross-section with immersed parts denoted by
 $B_{-}$
and
 $B_{+}$
; their wetted boundaries are
 $S_{-}$
and
 $S_{+}$
respectively. The cross-section of the infinitely thin layer of brash ice
 $F$
consists of three parts, two of which lie on the
 $x$
-axis outside
 $|x|>a$
and the third one is between
 $x=-b$
and
 $x=+b$
;
 $W$
is the cross-section of the water domain.

We suppose that
 $\widehat{B}\setminus \overline{\mathbb{R}_{-}^{2}}$
– the part of the body located above the surface of water covered by the brash ice – is a non-empty domain, whereas the immersed part
 $B=\widehat{B}\cap \mathbb{R}_{-}^{2}$
is the union of a finite number of domains (in particular, it may be a single domain). Thus,
 $D=\widehat{B}\cap \partial \mathbb{R}_{-}^{2}$
consists of the same number of non-empty intervals of the
 $x$
-axis; see figure 1, where
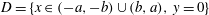 $D=\{x\in (-a,-b)\cup (b,a),\,y=0\}$
in the case of two immersed parts. We suppose that
 $W$
is
 $\mathbb{R}_{-}^{2}\setminus \overline{B}$
. Furthermore, we assume that
 $W$
is a Lipschitz domain, and so the unit normal
 $\boldsymbol{n}$
pointing to the exterior of
 $W$
is defined almost everywhere on
 $\partial W$
. Finally, we denote by
 $S=\partial \widehat{B}\cap \mathbb{R}_{-}^{2}$
the wetted curve (the number of its components is equal to the number of immersed domains), whereas
 $F=\partial \mathbb{R}_{-}^{2}\setminus \overline{D}$
is the infinitely thin layer of the brash ice covering the free surface at rest.
To describe the small-amplitude coupled motion of the system it is standard to apply the linear setting, in which case the first-order unknowns are used. These are the velocity potential
 ${\it\Phi}(x,y;t)$
and the vector column
 $\boldsymbol{q}(t)$
describing the motion of the body. This vector has the following three components:
-
(i)
 $q_{1}$
and
$q_{2}$
are the displacements of the centre of mass in the horizontal and vertical directions, respectively, from its rest position
$(x^{(0)},y^{(0)})$
;
-
(ii)
$q_{3}$
is the angle of rotation about the axis that goes through the centre of mass orthogonally to the
$(x,y)$
-plane (the angle is measured from the
$x$
- to the
$y$
-axis).


On the surface
 $F$
, the brash ice is characterised by a non-negative function
 ${\it\sigma}$
equal to the ratio of the local area density of the brash ice to the constant volume density of the water. (See, for example, Peters Reference Peters1950, p. 321, who supposed both densities to be constant; more details can be found in Gabov & Sveshnikov Reference Gabov and Sveshnikov1991, §§ 1.2 and 1.3.) The values of
 ${\it\sigma}$
are less than or equal to one, and we assume that
 ${\it\sigma}$
is constant throughout
 $F$
; the value of this constant is defined by the water salinity.
We omit relations governing the general time-dependent motion (see Kuznetsov Reference Kuznetsov2011 for details concerning a freely floating body and the papers just cited for the time-dependent boundary condition on
 $F$
) and turn directly to the time-harmonic oscillations of the system, for which purpose we use the ansatz
 $$\begin{eqnarray}({\it\Phi}(x,y,t),\boldsymbol{q}(t))=\text{Re}\{\text{e}^{-\text{i}{\it\omega}t}({\it\varphi}(x,y),\text{i}{\bf\chi})\},\end{eqnarray}$$
where
 ${\it\omega}>0$
is the radian frequency,
 ${\it\varphi}\in H_{loc}^{1}(W)$
is a complex-valued function bounded at infinity and
 ${\bf\chi}\in \mathbb{C}^{3}$
. Then the governing relations for
 $({\it\varphi},{\bf\chi})$
are as follows:
 $$\begin{eqnarray}\displaystyle & \displaystyle {\rm\nabla}^{2}{\it\varphi}=0\quad \text{in }W; & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \partial _{y}{\it\varphi}={\it\nu}({\it\varphi}+{\it\sigma}\partial _{y}{\it\varphi})\quad \text{on }F,\text{ where }{\it\nu}={\it\omega}^{2}/g; & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \partial _{\boldsymbol{n}}{\it\varphi}={\it\omega}\,{\bf\chi}^{\text{T}}\boldsymbol{N}\Big(={\it\omega}\mathop{\sum }_{1}^{3}N_{j}{\it\chi}_{j}\Big)\quad \text{on }S; & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle \boldsymbol{{\rm\nabla}}{\it\varphi}\rightarrow 0\quad \text{as }y\rightarrow -\infty ; & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle {\it\omega}^{2}\unicode[STIX]{x1D640}{\bf\chi}=-{\it\omega}\int _{S}{\it\varphi}\boldsymbol{N}\,\text{d}s+g\,\unicode[STIX]{x1D646}{\bf\chi}. & \displaystyle\end{eqnarray}$$
Here
 $\boldsymbol{{\rm\nabla}}=(\partial _{x},\partial _{y})$
is the spatial gradient and
 $g>0$
is the acceleration due to gravity that acts in the direction opposite to the
 $y$
-axis;
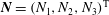 $\boldsymbol{N}=(N_{1},N_{2},N_{3})^{\text{T}}$
(the operation
 $^{\text{T}}$
transforms a vector row into a vector column and vice versa), where
 $(N_{1},N_{2})^{\text{T}}=\boldsymbol{n}$
,
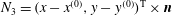 $N_{3}=(x-x^{(0)},y-y^{(0)})^{\text{T}}\times \boldsymbol{n}$
and
 $\times$
stands for the vector product. In the equations of the body motion (2.6), the
 $3\times 3$
matrices are as follows:
 $$\begin{eqnarray}\unicode[STIX]{x1D640}=\left(\begin{array}{@{}ccc@{}}I^{M} & 0 & 0\\ 0 & I^{M} & 0\\ 0 & 0 & I_{2}^{M}\end{array}\right)\quad \text{and}\quad \unicode[STIX]{x1D646}=\left(\begin{array}{@{}ccc@{}}0 & 0 & 0\\ 0 & I^{D} & I_{x}^{D}\\ 0 & I_{x}^{D} & I_{xx}^{D}+I_{y}^{B}\end{array}\right).\end{eqnarray}$$
The positive elements of the mass/inertia matrix
 $\unicode[STIX]{x1D640}$
are
 $$\begin{eqnarray}I^{M}={\it\rho}_{0}^{-1}\int _{\widehat{B}}{\it\rho}(x,y)\,\text{d}x\,\text{d}y\quad \text{and}\quad I_{2}^{M}={\it\rho}_{0}^{-1}\int _{\widehat{B}}{\it\rho}(x,y)[(x-x^{(0)})^{2}+(y-y^{(0)})^{2}]\text{d}x\,\text{d}y,\end{eqnarray}$$
where
 ${\it\rho}(x,y)\geqslant 0$
is the density distribution within the body and
 ${\it\rho}_{0}>0$
is the constant density of water. The first term on the right-hand side of (2.6) is due to the hydrodynamic pressure, whereas the second one is related to the buoyancy (see, for example, John Reference John1949). The non-zero elements of the matrix
 $\unicode[STIX]{x1D646}$
are
 $$\begin{eqnarray}\displaystyle & \displaystyle I^{D}=\int _{D}\text{d}x>0,\quad I_{x}^{D}=\int _{D}(x-x^{(0)})\,\text{d}x, & \displaystyle\end{eqnarray}$$
 $$\begin{eqnarray}\displaystyle & \displaystyle I_{xx}^{D}=\int _{D}(x-x^{(0)})^{2}\,\text{d}x>0,\quad I_{y}^{B}=\int _{B}(y-y^{(0)})\,\text{d}x\,\text{d}y. & \displaystyle\end{eqnarray}$$
It should be noted that the matrix
 $\unicode[STIX]{x1D646}$
is symmetric.
First, we suppose that
 ${\it\nu}{\it\sigma}\in [0,1)$
, which restricts the range of frequencies because
 ${\it\sigma}$
is a given constant. Under this assumption, the problem is studied in §§ 3 and 4; the case when
 ${\it\nu}{\it\sigma}\geqslant 1$
is considered in § 5. For
 ${\it\nu}{\it\sigma}\in [0,1)$
the boundary condition (2.3) is equivalent to
 $$\begin{eqnarray}\partial _{y}{\it\varphi}={\it\nu}^{({\it\sigma})}{\it\varphi}\quad \text{on }F,\quad \text{where }{\it\nu}^{({\it\sigma})}={\it\nu}/(1-{\it\nu}{\it\sigma})>{\it\nu}.\end{eqnarray}$$
This boundary condition is of the same form as in the case of open water when the coefficient
 ${\it\nu}$
is on the right-hand side instead of
 ${\it\nu}^{({\it\sigma})}$
. The parameter
 ${\it\nu}$
has the following expression in terms of
 ${\it\nu}^{({\it\sigma})}$
:
 $$\begin{eqnarray}{\it\nu}={\it\nu}^{({\it\sigma})}/\big(1+{\it\sigma}{\it\nu}^{({\it\sigma})}\big)<{\it\nu}^{({\it\sigma})}.\end{eqnarray}$$
As in the problem describing waves on open water, it is natural to complement the Laplace equation (2.2) and the boundary condition (2.11) by the following radiation condition (it means that the potential (2.1) describes outgoing waves):
 $$\begin{eqnarray}\int _{W\cap \{|x|=b\}}|\partial _{|x|}{\it\varphi}-\text{i}{\it\nu}^{({\it\sigma})}{\it\varphi}|^{2}\,\text{d}s=o(1)\quad \text{as }b\rightarrow \infty .\end{eqnarray}$$
In relations (2.4), (2.6), (2.11) and (2.13),
 ${\it\omega}$
is a spectral parameter (in (2.11) and (2.13) it is involved through
 ${\it\nu}^{({\it\sigma})}$
), which is sought together with the eigenvector
 $({\it\varphi},{\bf\chi})$
.
Since
 $W$
is a Lipschitz domain and
 ${\it\varphi}\in H_{loc}^{1}(W)$
, it is natural to understand the problem, namely relations (2.2), (2.4) and (2.11), in the sense of the integral identity
 $$\begin{eqnarray}\int _{W}\boldsymbol{{\rm\nabla}}{\it\varphi}\boldsymbol{{\rm\nabla}}{\it\psi}\,\text{d}x\,\text{d}y={\it\nu}^{({\it\sigma})}\int _{F}{\it\varphi}\,{\it\psi}\,\text{d}x+{\it\omega}\int _{S}{\it\psi}\,\boldsymbol{N}^{\text{T}}{\bf\chi}\,\text{d}s,\end{eqnarray}$$
which must hold for an arbitrary smooth
 ${\it\psi}$
having a compact support in
 $\overline{W}$
, whereas the remaining conditions (2.5) and (2.13) specify the behaviour of
 ${\it\varphi}$
at infinity.
The problem formulated above must be augmented by the following subsidiary conditions concerning the equilibrium position (see John Reference John1949):
-
(i)
$I^{M}=\int _{B}\text{d}x\,\text{d}y$
(Archimedes’ law – the mass of the displaced liquid is equal to that of the body); -
(ii)
$\int _{B}(x-x^{(0)})\,\text{d}x\,\text{d}y=0$
(the centre of buoyancy lies on the same vertical line as the centre of mass); -
(iii) the
$2\times 2$
matrix
$\unicode[STIX]{x1D646}^{\prime }$
that is in the lower right corner of
$\unicode[STIX]{x1D646}$
is positive definite.

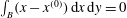


The last of these requirements yields the stability of the body equilibrium position, which is understood in the classical sense that any instantaneous infinitesimal disturbance causes position changes which remain infinitesimal, except for purely horizontal drift, for all subsequent times.
3 Equipartition of energy
It is known (see, for example, Kuznetsov et al. Reference Kuznetsov, Maz’ya and Vainberg2002, § 2.2.1), that a potential satisfying relations (2.2), (2.5), (2.11) and (2.13) has the same asymptotic representation at infinity as Green’s function, namely
 $$\begin{eqnarray}\left.\begin{array}{@{}c@{}}{\it\varphi}(x,y)=A_{\pm }(y)\,\text{e}^{\text{i}{\it\nu}^{({\it\sigma})}|x|}+r_{\pm }(x,y),\\ |r_{\pm }|^{2},\,|\boldsymbol{{\rm\nabla}}r_{\pm }|=O([x^{2}+y^{2}]^{-1})\text{ as }x^{2}+y^{2}\rightarrow \infty .\end{array}\right\}\end{eqnarray}$$
Moreover, the following equality holds for the coefficients:
 $$\begin{eqnarray}{\it\nu}^{({\it\sigma})}\int _{-\infty }^{0}\left(|A_{+}(y)|^{2}+|A_{-}(y)|^{2}\right)\text{d}y=-\text{Im}\int _{S}\overline{{\it\varphi}}\,\partial _{\boldsymbol{n}}{\it\varphi}\,\text{d}s.\end{eqnarray}$$
Assuming that
 $({\it\varphi},{\bf\chi})$
is a solution of the problem formulated in § 2, we rearrange the last formula by virtue of the coupling conditions (2.4) and (2.6), thus obtaining (see details in Kuznetsov (Reference Kuznetsov2015), § 3)
 $$\begin{eqnarray}{\it\nu}^{({\it\sigma})}\int _{-\infty }^{0}\left(|A_{+}(y)|^{2}+|A_{-}(y)|^{2}\right)\text{d}y=\text{Im}\{{\it\omega}^{2}\,\overline{{\bf\chi}}^{\text{T}}\unicode[STIX]{x1D640}{\bf\chi}-g\overline{{\bf\chi}}^{\text{T}}\unicode[STIX]{x1D646}{\bf\chi}\}.\end{eqnarray}$$
In the same way as in Kuznetsov & Motygin (Reference Kuznetsov and Motygin2011, Reference Kuznetsov and Motygin2012), this yields the following assertion about the kinetic and potential energy of the water motion.
Proposition 1. Let
 $({\it\varphi},{\bf\chi})$
be a solution of problem (2.2)–(2.6), (2.13), then
 $$\begin{eqnarray}\int _{W}|\boldsymbol{{\rm\nabla}}{\it\varphi}|^{2}\,\text{d}x\,\text{d}y<\infty \quad \text{and}\quad {\it\nu}^{({\it\sigma})}\int _{F}|{\it\varphi}|^{2}\,\text{d}x<\infty \,,\end{eqnarray}$$
that is,
 ${\it\varphi}\in H^{1}(W)$
. Moreover, the following equality holds:
 $$\begin{eqnarray}\int _{W}|\boldsymbol{{\rm\nabla}}{\it\varphi}|^{2}\,\text{d}x\,\text{d}y+{\it\omega}^{2}\overline{{\bf\chi}}^{\text{T}}\unicode[STIX]{x1D640}{\bf\chi}={\it\nu}^{({\it\sigma})}\int _{F}|{\it\varphi}|^{2}\,\text{d}x+g\,\overline{{\bf\chi}}^{\text{T}}\unicode[STIX]{x1D646}{\bf\chi}.\end{eqnarray}$$
Here the kinetic energy of the water/body system is on the left-hand side, whereas we have the potential energy of the coupled motion on the right-hand side. The latter takes into account that the water is covered by the brash ice, and so the last formula generalises the energy equipartition equality valid when a body is freely floating in open water.
Proposition 1 shows that if
 $({\it\varphi},{\bf\chi})$
is a solution with complex-valued components, then its real and imaginary parts separately satisfy the problem. This allows us to consider
 $({\it\varphi},{\bf\chi})$
as an element of the real product space
 $H^{1}(W)\times \mathbb{R}^{3}$
in what follows; an equivalent norm in
 $H^{1}(W)$
is defined by the sum of two quantities (3.4).
Definition 1. Let the subsidiary conditions concerning the equilibrium position (see § 2) hold for the freely floating body
 $\widehat{B}$
. A non-trivial real solution
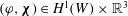 $({\it\varphi},{\bf\chi})\in H^{1}(W)\times \mathbb{R}^{3}$
of the problem (2.14), (2.6) and (2.13) is called a mode trapped by this body, whereas the corresponding value of
 ${\it\omega}$
is referred to as a trapping frequency.
4 Motionless bodies trapping waves in the presence of the brash ice
In Kuznetsov (Reference Kuznetsov2011), a semi-inverse procedure was used for the construction of motionless bodies freely floating in open water of infinite depth and trapping a two-dimensional mode at the frequency
 ${\it\omega}$
given arbitrarily. The idea of the procedure is to seek bodies for a prescribed trapped mode. Subsequently, Kuznetsov & Motygin (Reference Kuznetsov and Motygin2012, Reference Kuznetsov and Motygin2015) developed this approach and constructed various axisymmetric trapping bodies, motionless and heaving, and sets of multiple bodies some of which are motionless, whereas the others heave. In this section, we first apply the same idea to construct a family of motionless bodies trapping waves in the water covered by the brash ice and then consider the effect of the brash ice by comparing these bodies with those trapping waves in open water.
4.1 Construction of a family of motionless trapping bodies
Let
 ${\it\omega}>0$
be fixed so that
 ${\it\nu}={\it\omega}^{2}/g$
satisfies the inequality
 ${\it\nu}<{\it\sigma}^{-1}$
, where the constant
 ${\it\sigma}>0$
is given, thus restricting the range of admissible frequencies. In order to obtain a family of immersed parts of motionless bodies that trap waves in the water covered by the brash ice we follow the considerations used in §§ 3 and 4 of Kuznetsov (Reference Kuznetsov2011) with
 ${\it\nu}$
changed to
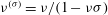 ${\it\nu}^{({\it\sigma})}={\it\nu}/(1-{\it\nu}{\it\sigma})$
.
Let us consider the following motionless mode
 $({\it\varphi}_{0},(\mathbf{0},0)^{\text{T}})$
, where
 $\mathbf{0}\in \mathbb{R}^{2}$
denotes the zero-displacement vector,
 $0$
stands for the zero angle of rotation and
 $$\begin{eqnarray}{\it\varphi}_{0}(x,y)=\frac{g^{2}}{{\it\omega}^{3}}{\it\phi}_{0}({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y),\end{eqnarray}$$
whereas the non-dimensional velocity potential
 ${\it\phi}_{0}$
is as follows:
 $$\begin{eqnarray}{\it\phi}_{0}({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)=\int _{0}^{\infty }\frac{k\,\text{e}^{k{\it\nu}^{({\it\sigma})}y}}{k-1}\left[\sin k({\it\nu}^{({\it\sigma})}x-{\rm\pi})-\sin k({\it\nu}^{({\it\sigma})}x+{\rm\pi})\right]\text{d}k.\end{eqnarray}$$
Here, the integral is understood as the usual improper integral because its integrand is bounded; indeed, the location of zeros coincides for the denominator and numerator. Moreover, we have that
 $$\begin{eqnarray}{\it\phi}_{0}({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)=(2\,{\it\nu}^{({\it\sigma})})^{-1}\left[G_{x}(x,y;-{\rm\pi}/{\it\nu}^{({\it\sigma})},0)-G_{x}(x,y;{\rm\pi}/{\it\nu}^{({\it\sigma})},0)\right],\end{eqnarray}$$
where
 $G(x,y;{\it\xi},{\it\eta})$
is Green’s function of the time-harmonic water-wave problem (see Kuznetsov et al.
Reference Kuznetsov, Maz’ya and Vainberg2002, § 1.2.1, where the properties of
 $G$
are described). Therefore,
 $$\begin{eqnarray}\partial _{y}{\it\phi}_{0}-{\it\nu}^{({\it\sigma})}{\it\phi}_{0}=0\quad \text{for }y=0\text{ and }{\it\nu}^{({\it\sigma})}x\neq \pm {\rm\pi},\end{eqnarray}$$
and
 $$\begin{eqnarray}{\it\phi}_{0}(x,y)=O([x^{2}+y^{2}]^{-1}),\quad |\boldsymbol{{\rm\nabla}}{\it\phi}_{0}(x,y)|=O([x^{2}+y^{2}]^{-3/2}),\end{eqnarray}$$
as
 $x^{2}+y^{2}\rightarrow \infty$
. These estimates yield that the kinetic and potential energy is finite for
 ${\it\phi}_{0}$
in every domain away from the singularities of this function.
The next crucial point of the inverse procedure is to use streamlines corresponding to the velocity potential (4.2) in order to define two immersed contours of a freely floating trapping body that is symmetric about the
 $y$
-axis and has
 $x^{(0)}=0$
. The last property is guaranteed by a proper choice of density distribution, which is always possible for a symmetric body. Moreover, it is possible to choose this distribution so that
 $y^{(0)}$
is sufficiently close to the ordinate of the lowest points of the body, thus yielding that all of the subsidiary conditions hold.
Taking a harmonic conjugate to
 ${\it\phi}_{0}$
in the form
 $$\begin{eqnarray}{\it\psi}_{0}({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)=\int _{0}^{\infty }\frac{k\,\text{e}^{k{\it\nu}^{({\it\sigma})}y}}{k-1}\left[\cos k({\it\nu}^{({\it\sigma})}x-{\rm\pi})-\cos k({\it\nu}^{({\it\sigma})}x+{\rm\pi})\right]\text{d}k,\end{eqnarray}$$
we see that this stream function decays at infinity. Let us list several other properties of
 ${\it\psi}_{0}$
(see their proof in Kuznetsov et al.
Reference Kuznetsov, Maz’ya and Vainberg2002, pp. 178–179) used for construction of a family of bodies trapping the mode
 $({\it\varphi}_{0},(\mathbf{0},0)^{\text{T}})$
. Since
 ${\it\psi}_{0}$
is an odd function of
 $x$
, we formulate these properties only for
 $x>0$
.
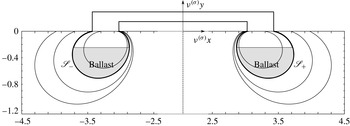
Level lines of the stream function
 ${\it\psi}_{0}$
plotted in non-dimensional coordinates. An example of the wetted contours bounding a motionless trapping body is shown in bold and denoted by
 ${\mathcal{S}}_{-}$
and
 ${\mathcal{S}}_{+}$
; other pairs of symmetric streamlines can also be considered as boundaries of immersed parts of trapping bodies. In order to contract the width of the figure, a reduced horizontal scale is applied on the interval (
 $-2.5$
,
 $2.5$
).

The trace
 ${\it\psi}_{0}({\it\nu}^{({\it\sigma})}x,0)$
has only one positive zero
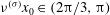 ${\it\nu}^{({\it\sigma})}x_{0}\in (2{\rm\pi}/3,{\rm\pi})$
and
 $$\begin{eqnarray}{\it\psi}_{0}({\it\nu}^{({\it\sigma})}x,0)<0\quad \text{on }(0,{\it\nu}^{({\it\sigma})}x_{0}).\end{eqnarray}$$
Moreover, this function increases monotonically from
 $0$
to
 $+\infty$
on
 $[{\it\nu}^{({\it\sigma})}x_{0},{\rm\pi})$
and decreases monotonically from
 $+\infty$
to
 $0$
on
 $({\rm\pi},+\infty )$
. Therefore, for every non-dimensional
 $d>0$
the streamline
 $$\begin{eqnarray}{\mathcal{S}}_{+}=\{({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)\in \overline{\mathbb{R}_{-}^{2}}:\,x>0,\,{\it\psi}_{0}({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)=d\}\end{eqnarray}$$
(see the right-hand part of figure 2) connects two points that lie on the positive
 ${\it\nu}^{({\it\sigma})}x$
-axis on either side of the point
 $({\rm\pi},0)$
at which
 ${\it\psi}_{0}$
is infinite.
Thus, for the chosen
 ${\it\omega}$
and every
 $d>0$
the domain
 $B_{+}$
between
 $$\begin{eqnarray}S_{+}=\{(x,y)\in \overline{\mathbb{R}_{-}^{2}}:({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)\in {\mathcal{S}}_{+}\}\end{eqnarray}$$
and the
 $x$
-axis serves as the right immersed part of a single motionless trapping body
 $\widehat{B}$
obtained by connecting
 $B_{+}$
with the symmetric domain
 $B_{-}$
as shown in figure 2 for the corresponding domains in non-dimensional variables. Indeed, the Cauchy–Riemann equations imply that
 ${\it\varphi}_{0}$
satisfies the homogeneous Neumann condition on
 $S=S_{-}\cup S_{+}$
, and so the coupling condition (2.4) is fulfilled for the mode
 $({\it\varphi}_{0},(\mathbf{0},0)^{\text{T}})$
. The coupling condition (2.6) is also fulfilled for this mode because it reduces to the equality
 $$\begin{eqnarray}\int _{S_{-}\cup S_{+}}{\it\varphi}_{0}\,n_{y}\,\text{d}s=0.\end{eqnarray}$$
Indeed, the other two equalities are trivial by the symmetry of
 $S_{-}\cup S_{+}$
and the fact that the corresponding integrands are odd functions of
 $x$
. The proof that the last integral vanishes is based on the second Green’s formula and the asymptotic formulae (4.5) (see details in Kuznetsov Reference Kuznetsov2011).
4.2 The effect of the brash ice on motionless trapping bodies
The procedure described in § 4.1 rigorously establishes the existence of trapping bodies, but it does not present pictorially the effect of the brash ice, that is, how these bodies differ from those trapping waves in open water. In order to do this, we apply rescaling of specially chosen contours from the non-dimensional coordinates
 $({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)$
to
 $({\it\nu}x,{\it\nu}y)$
for which purpose the equality
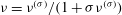 ${\it\nu}={\it\nu}^{({\it\sigma})}/(1+{\it\sigma}{\it\nu}^{({\it\sigma})})$
serves. Rescaling is realised in two different manners: by keeping the area of the immersed part fixed and by keeping the length of
 $D$
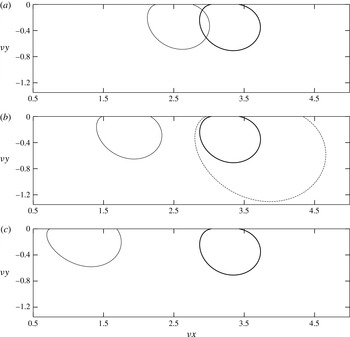
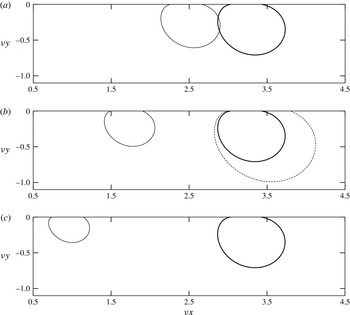
fixed. The corresponding results are shown in figures 3 and 4 respectively, where three values of frequency are considered to demonstrate the effect; the frequency is characterised by the product
 ${\it\nu}{\it\sigma}$
.
Examples of bodies trapping waves in water covered by the brash ice for
 ${\it\nu}{\it\sigma}=1/4$
(a);
 ${\it\nu}{\it\sigma}=1/2$
(b);
 ${\it\nu}{\it\sigma}=3/4$
(c). In each figure, the left-hand contour is the right-hand immersed part of a symmetric body trapping waves; the bold contour shows the location of the body that has the same area and traps waves in open water at the same frequency. The dashed line in (b) shows the contour from which the left-hand one is obtained by the scaling
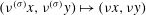 $({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)\mapsto ({\it\nu}x,{\it\nu}y)$
.

In figures 3(a–c) and 4(a–c), examples of symmetric bodies trapping waves in water covered by brash ice are shown. The bodies are represented by the boundaries of their right immersed parts; see the left-hand contour in each figure (cf. figure 2, where an example of the whole body is shown in the non-dimensional coordinates
 $({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)$
). The location of a body that traps waves in open water at the same frequency is indicated for comparison; it is plotted in bold (see the contour on the right-hand side of each figure). Both bodies have either the same area of the immersed part (the scaling adopted in figure 3) or the same length of
 $D$
(the scaling adopted in figure 4). The dashed lines in figures 3(b) and 4(b) show the contours from which the left-hand ones are obtained by the scaling
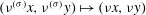 $({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)\mapsto ({\it\nu}x,{\it\nu}y)$
.
Thus figure 3(a–c) demonstrates the following properties of the obtained symmetric trapping bodies with the fixed immersed area. The spacing between two immersed parts is less for bodies that trap waves in water covered by the brash ice than for bodies that trap waves in open water. Moreover, this spacing decreases as the frequency of trapped waves increases, whereas the length of
 $D$
, on the contrary, increases together with the frequency.
The properties of symmetric trapping bodies with the fixed length of
 $D$
are as follows; see figure 4(a–c). The spacing between two immersed parts demonstrates the same behaviour as in the previous case, whereas the immersed area decreases as the frequency increases.
5 The effect of the brash ice when
${\it\nu}{\it\sigma}\geqslant 1$

Let
 $\widehat{B}$
be a freely floating body, that is, it satisfies all subsidiary conditions of § 2. For the matrices
 $\unicode[STIX]{x1D640}$
and
 $\unicode[STIX]{x1D646}$
corresponding to
 $\widehat{B}$
(see (2.7) and the following formulae that define the matrices’ elements), we denote by
 ${\it\lambda}_{\ast }$
the largest
 ${\it\lambda}$
such that
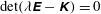 $\det ({\it\lambda}\unicode[STIX]{x1D640}-\unicode[STIX]{x1D646})=0$
.
Proposition 2. Let
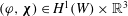 $({\it\varphi},{\bf\chi})\in H^{1}(W)\times \mathbb{R}^{3}$
be a solution of problem (2.2)–(2.6). If
 ${\it\omega}$
is such that
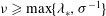 ${\it\nu}\geqslant \max \{{\it\lambda}_{\ast },{\it\sigma}^{-1}\}$
, where
 ${\it\lambda}_{\ast }$
corresponds to
 $\widehat{B}$
through
 $\unicode[STIX]{x1D640}$
and
 $\unicode[STIX]{x1D646}$
, then
 $({\it\varphi},{\bf\chi})$
is a trivial solution.
Examples of bodies trapping waves in water covered by the brash ice for
 ${\it\nu}{\it\sigma}=1/4$
(a);
 ${\it\nu}{\it\sigma}=1/2$
(b);
 ${\it\nu}{\it\sigma}=3/4$
(c). In each figure, the left-hand contour is the right-hand immersed part of a symmetric body trapping waves; the bold contour shows the location of the body that has the same length of
 $D$
and traps waves in open water at the same frequency. The dashed line in (b) shows the contour from which the left-hand one is obtained by the scaling
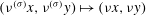 $({\it\nu}^{({\it\sigma})}x,{\it\nu}^{({\it\sigma})}y)\mapsto ({\it\nu}x,{\it\nu}y)$
.

Proof. Let
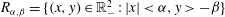 $R_{{\it\alpha},{\it\beta}}=\{(x,y)\in \mathbb{R}_{-}^{2}:|x|<{\it\alpha},y>-{\it\beta}\}$
, where
 ${\it\alpha},{\it\beta}>0$
are sufficiently large; for example, such that
 $B\subset R_{{\it\alpha}-1,{\it\beta}-1}$
. Applying the first Green’s formula, we write
 $$\begin{eqnarray}\displaystyle \int _{W\cap R_{{\it\alpha},{\it\beta}}}|\boldsymbol{{\rm\nabla}}{\it\varphi}|^{2}\,\text{d}x\,\text{d}y & = & \displaystyle \int _{S}{\it\varphi}\,\partial _{\boldsymbol{n}}{\it\varphi}\,\text{d}s+\int _{-{\it\alpha}}^{{\it\alpha}}[{\it\varphi}(x,y)\,\partial _{y}{\it\varphi}(x,y)]_{y=-{\it\beta}}^{y=0,x\in F}\,\text{d}x\nonumber\\ \displaystyle & & \displaystyle +\int _{-{\it\beta}}^{0}[{\it\varphi}(x,y)\,\partial _{x}{\it\varphi}(x,y)]_{x=-{\it\alpha}}^{x={\it\alpha}}\,\text{d}y,\end{eqnarray}$$
where the Laplace equation is taken into account. The assumptions imposed on
 ${\it\varphi}$
yield that: (1) there exists a sequence
 $\{{\it\alpha}_{k}\}_{k=1}^{\infty }$
such that
 ${\it\alpha}_{k}\rightarrow \infty$
as
 $k\rightarrow \infty$
and the last integral with
 ${\it\beta}=\infty$
and
 ${\it\alpha}={\it\alpha}_{k}$
tends to zero as
 $k\rightarrow \infty$
; (2) for all
 ${\it\alpha}>0$
we have that
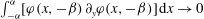 $\int _{-{\it\alpha}}^{{\it\alpha}}[{\it\varphi}(x,-{\it\beta})\,\partial _{y}{\it\varphi}(x,-{\it\beta})]\,\text{d}x\rightarrow 0$
as
 ${\it\beta}\rightarrow \infty$
. Passing to the limit in (5.1), first as
 ${\it\beta}\rightarrow \infty$
and then as
 ${\it\alpha}_{k}\rightarrow \infty$
, we obtain
 $$\begin{eqnarray}\int _{W}|\boldsymbol{{\rm\nabla}}{\it\varphi}|^{2}\,\text{d}x\,\text{d}y-\int _{F}{\it\varphi}(x,0)\,\partial _{y}{\it\varphi}(x,0)\,\text{d}x=\int _{S}{\it\varphi}\,\partial _{\boldsymbol{n}}{\it\varphi}\,\text{d}s.\end{eqnarray}$$
Here the integral over
 $F$
vanishes when
 ${\it\nu}={\it\sigma}^{-1}$
(in this case, the boundary condition (2.3) reduces to
 ${\it\varphi}=0$
on
 $F$
); if
 ${\it\nu}>{\it\sigma}^{-1}$
, this integral is equal to
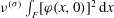 ${\it\nu}^{({\it\sigma})}\int _{F}[{\it\varphi}(x,0)]^{2}\,\text{d}x$
, which is a consequence of (2.11). In both cases, the left-hand side of (5.2) is positive for a non-trivial
 ${\it\varphi}$
(in the second case, because
 ${\it\nu}^{({\it\sigma})}<0$
).
On the other hand, it follows from (2.4) and (2.6) that
 $$\begin{eqnarray}\int _{S}{\it\varphi}\,\partial _{\boldsymbol{n}}{\it\varphi}\,\text{d}s={\it\omega}{\bf\chi}^{\text{T}}\int _{S}{\it\varphi}\,\boldsymbol{N}\,\text{d}s=-g^{-1}{\bf\chi}^{\text{T}}[{\it\nu}\unicode[STIX]{x1D640}-\unicode[STIX]{x1D646}]{\bf\chi},\end{eqnarray}$$
and so the right-hand side term of (5.2) is non-positive when
 ${\it\nu}\geqslant {\it\lambda}_{\ast }$
. Thus, this contradicts the positivity of the left-hand side with a non-trivial
 ${\it\varphi}$
when
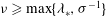 ${\it\nu}\geqslant \max \{{\it\lambda}_{\ast },{\it\sigma}^{-1}\}$
. This completes the proof of the proposition.◻
6 Concluding remarks
This note extends our previous work in two directions, both of which are related to the presence of brash ice covering the free surface of the water. Concerning motionless trapping bodies, it has been shown that there exist two-dimensional bodies with a vertical axis of symmetry and two immersed parts and the following properties. Each of these bodies is freely floating but motionless and traps some time-harmonic mode provided its frequency is bounded by a constant characterising the brash ice. Thus, there is a coupled motion of the water covered by this ice that does not radiate waves to infinity in the presence of such a body. Therefore, in the absence of viscosity, this oscillation will persist forever.
On the other hand, for every freely floating body there exists a bound for frequencies such that no waves exist at frequencies exceeding this bound; as in the case of the absence of propagating waves considered by Peters (Reference Peters1950), it depends on the constant that characterises the brash ice. Moreover, unlike uniqueness theorems known hitherto and concerning time-harmonic water waves in the presence of freely floating bodies, this result does not involve any geometric restriction to be imposed on the body.