


NOMENCLATURE
- MLP
minimal learning parameter
- NNs
neural networks
- FTCO
finite-time convergent observer
- RBF
radial basis function
- MIMO
multi-input, multi-output
- ERF
earth reference frame
- CV
centre of volume
- BRF
body reference frame
- DOF
degree of freedom
1.0 INTRODUCTION
As a novel aircraft, the stratospheric airship exhibits enormous potential in real-time surveillance, telecommunication, scientific experiments, and other fields due to its unique capability(Reference Azinheira, de Paiva, Ramos and Beuno1,Reference Lee, Kim and Yeom11,Reference Liao and Pasternak14) , implying that high-precision trajectory tracking is necessary to complete diverse tasks. However, natural nonlinearity, the high-coupled property of the airship and external disturbances hinder reaching and accurately tracking a time-varying trajectory and make the control scheme design process quite complicated(Reference Gao, Huang, Zhou and Song6,Reference Khoury10,Reference Qin, Li, Sun and Wang18,Reference Sangjong, Lee, Daeyeon and Hyochoong20,Reference Yang and Yan27,Reference Zheng, Huo and Wu39,Reference Zhu, Pang, Sun, Gao, Sun and Chen42) . Additionally, for an underactuated airship, the trajectory tracking control design is more daunting due to the actuators of the airship not providing independent forces or moments in all degrees of freedom.
In recent decades, much literature offering various trajectory tracking control approaches for the airship has emerged. The PID control algorithm(Reference de Paiva, Bueno, Gomes, Ramos and Bergerman3) was developed to perform five flight operating modes: launching, cruising, turning, hovering, and landing. Based on a command-filtered and back-stepping methodology, Ding et al.(Reference Han, Wang, Chen and Duan8) proposed a nonlinear controller to force an airship to move along a desired trajectory under a time-invariant wind field. Together with nonsingular terminal sliding mode control approach, a robust nonlinear trajectory tracking control law(Reference Yang and Yan28) that involves neural networks (NNs) approximation was proposed for an airship. In Ref. (Reference Sun and Zheng22), a non-certainty equivalence adaptive trajectory tracking control structure was formulated for a fully actuated airship subject to parametric uncertainties. By adopting a time-varying tan-type barrier Lyapunov function, Zheng et al.(Reference Zheng, Guan, Ma and Zhu37,Reference Zheng, Huang, Xie and Zhu38,Reference Zheng, Sun and Xie40) presented output-constrained control schemes that could effectively implement error-constrained trajectory tracking or path-following, and constructed radial basis function (RBF) NNs to approximate the uncertain dynamics and disturbances of an airship. It should be noted that the aforementioned studies can warrant only that the tracking errors are uniformly ultimately bounded. However, in practical applications, we expect the transient and steady-state tracking performance to be at the user’s disposal.
Fortunately, fixed-time or finite-time control methods can improve the transient tracking performance and provide a faster decay rate, as exhibited in Refs. (Reference Xu, Wang and Zhen25), (Reference Yang26), (Reference Zhang, Yu and Yan33) and (Reference Zheng, Feroskhan and Sun36). Moreover, various fruitful studies have demonstrated that prescribed performance control techniques can effectively guarantee the desired transient and steady tracking behaviour(Reference Zhang and Yang32,Reference Zhou and Song41) . For path-following control of a surface vessel, Zheng et al.(Reference Zheng and Feroskhan35) developed a robust adaptive control law that obtained prescribed tracking performance. For multi-input, multi-output (MIMO) systems, various control approaches with prescribed performances have been investigated(Reference Bechlioulis and Rovithakis2,Reference Shi, Luo and Li21) . Yet, it is worth noting that all of these works rely on the key assumption that the full state is measurable. When only the position and attitude are measurable, the full-state feedback control framework likely performs very poorly or is unstable.
During actual flight under a full-state feedback control scheme, once the on-board sensors fail, the behaviour of the airship becomes uncontrollable. Therefore, an airship control framework relying on position and attitude information becomes practical and significant. Thus, numerous control structures that involve an observer have been developed(Reference Elhaki and Shojaei4,Reference Li, Ma, Luo and Yang12,Reference Park, Kwon and Kim16,Reference Peng and Wang17) . For autonomous underwater vehicles, Peng et al.(Reference Peng and Wang17) presented an output feedback controller, where the unmeasured velocities and external disturbances are measured by an extended state observer integrally. Because of the various applications of airships, high-accuracy trajectory tracking is frequently an indispensable component of the required assignment. Although studies on trajectory tracking are productive, the current published works rarely provide an explicit and quantitative description of the convergence set, the settling time, and the decay rate of trajectory tracking errors for an airship subject to disturbances, uncertain dynamics, and immeasurable velocities.
From these results, this paper presents a robust neuroadaptive output-feedback horizontal trajectory tracking control scheme for an airship with prescribed performance. For velocities that are unmeasured, a finite-time convergent observer (FTCO) is constructed to obtain the estimations. Motivated by the works in Ref. (Reference Miao, Li and Luo15) and (Reference Zhang and Zhang31), we employ the minimal learning parameter (MLP) techniques to address environmental disturbances and model uncertainties simultaneously. The main contributions and features of this paper are as follows: (1) by blending a speed function and four error transformations in the control algorithm, the control strategy can guarantee that the tracking errors converge to a prescribed residual set before a preassigned finite time with a convergence rate greater than or equal to a prespecifiable value; (2) unlike most existing works demanding full-state measurability, the proposed control scheme can realise highly accurate trajectory tracking utilizing only the position and attitude information; (3) compared with most of the NNs-based controllers, one of the advantages of the proposed control scheme lies in the fact that only two learning parameters need to be updated on-line to handle disturbances and uncertain dynamics, which improves the system’s robustness and reduces the computational burden.
2.0 PRELIMINARIES
2.1 Notations
Throughout this paper, for a scalar,  $|{\cdot}|$
means the absolute value; for any vectors,
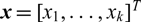 $\textbf{\textit{x}} = [ {x_1},\break \ldots, {x_k}]^T$
and
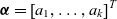 $\boldsymbol\alpha = {\left[ {{a_1}, \ldots ,{a_k}} \right]^T}$
,
 $si{g^a}(\textbf{\textit{x}})$
is expressed as
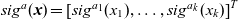 $si{g^a}(\textbf{\textit{x}}) = {\left[ {si{g^{{a_1}}}({x_1}),\break \ldots ,si{g^{{a_k}}}({x_k})} \right]^T}$
, where
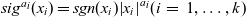 $si{g^{{a_i}}}({x_i}) = sgn({x_i}){\left| {{x_i}} \right|^{{a_i}}}(i\,=\,1, \ldots ,k)$
, with
 $sgn( \cdot )$
being the signum function. Define
 $\left\| \cdot \right\|$
as the Euclidean norm of a vector or 2-norm of a matrix.
2.2 RBF NNs approximation
For any unknown smooth nonlinear function 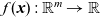 $f(\textbf{\textit{x}}):{\mathbb{R}^m} \to \mathbb{R}$
, the following RBF NNs can approximate it over a compact set
 $\Omega \subset {\mathbb{R}^m}$
:
 \begin{equation}f(\textbf{\textit{x}}) = {\boldsymbol\theta ^{*T}}\boldsymbol\phi (\textbf{\textit{x}}) + \epsilon(\textbf{\textit{x}})\end{equation}
where  $\epsilon (\textbf{\textit{x}})$
is a bounded function denoting the approximation error. By supplying sufficient hidden neurons, an acceptable small value of the approximation error
 $\boldsymbol\epsilon(\textbf{\textit{x}})$
can be obtained.(Reference Ge, Hang, Lee and Zhang7)
 $\textbf{\textit{x}} \in \boldsymbol\Omega $
indicates the input vector and the radial basis function vector is represented by
 $\boldsymbol\phi (\textbf{\textit{x}}) = {\left[ {{\phi _1}(\textbf{\textit{x}}), \ldots ,{\phi _k}(\textbf{\textit{x}})} \right]^T} \in {\mathbb{R}^k}$
, with
 $k\,>\,1$
indicating the number of nodes and
 ${\phi _i}(\textbf{\textit{x}})$
chosen as the Gaussian function
 \begin{equation}{\phi _i} = exp\left( { - {\frac{{{\left\| {\textbf{\textit{x}} - {\textbf{\textit{p}}_i}} \right\|}^2}}{\textbf{\textit{q}}_i^2}}} \right)\end{equation}
where  ${\textbf{\textit{p}}_i} \in {\mathbb{R}^m}$
is the centre and q i denotes the spread. The ideal weight vector
 ${\boldsymbol\theta ^*} \in {\mathbb{R}^k}$
is typically computed as
 \begin{equation}{\boldsymbol\theta^*} = arg\mathop {min}\limits_{\hat{\boldsymbol\theta} \in {\mathbb{R}^k}} \left\{ {\mathop {sup}\limits_{x \in \Omega } \left| {f(\textbf{\textit{x}}) - {{\hat{\boldsymbol\theta}}^T}\boldsymbol\phi (\textbf{\textit{x}})} \right|} \right\}\end{equation}
where  $\hat{\boldsymbol\theta} $
is the estimation of
 ${\boldsymbol\theta ^*}$
.
2.3 Definitions and lemmas
Lemma 1 Lemma 1 Consider the finite-time convergent differentiator (Reference Yi, Wang and Li29)described as
 \begin{equation}\left\{ \begin{matrix} {{\dot{x}}_1} = {x_2} - {\zeta _1}{{\left| {{x_1} - {x^*}} \right|}^{1 - 1/p}}sgn({x_1} - {x}^*) \\[3pt] {{\dot{x}}_2} = - {\zeta _2}{{\left| {{x_1} - {x^*}} \right|}^{1 - 2/p}}sgn({x_1} - {x}^*) \end{matrix} \right.\end{equation}
where  ${\zeta _1}\,>\,0$
,
 ${\zeta _2}\,>\,0$
, and
 $p\,>\,2$
are design parameters and x 1and x 2are the estimations of x *and
 ${\dot{x}^*}$
respectively. If
 ${\ddot x^*}$
is bounded, namely,
 $0 \le \left| {{{\ddot x}^*}} \right| < L$
, where L is an unknown positive constant, then the estimation errors
 ${e_1} = {x^*} - {x_1}$
and
 ${e_2} = {\dot{x}^*} - {x_2}$
are uniformly ultimately bounded and can approach zero within a finite time.
Lemma 2 Lemma 2 For any  $x \in \mathbb{R}$
and
 $\Theta \in {\mathbb{R}^+ }$
, we have (Reference Jin9)
 \begin{equation}0 \le \left| x \right| \le \Theta + {\frac{{x^2}}{\sqrt {{x^2} + \Theta } }}\end{equation}
To achieve a guaranteed transient and steady-state tracking performance, the following speed function is employed:
 \begin{equation}\beta (t) = \left\{ \begin{matrix} {\dfrac{{T^4}{e^t}}{(1 - {c_f}){{(T - t)}^4} + {c_f}{T^4}{e^t}}} & {,0 \le t \le T} \\ \\[-6pt] {\frac{1}{{c_f}}} & {,t \ge T} \\ \end{matrix} \right.\end{equation}
where 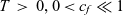 $T\,>\,0,0 < {c_f} \ll 1$
represent the preselected finite settling time and pre-chosen error transformation coefficient, respectively. Referring to the work of Zhao et al. (Reference Zhao, Song, Ma and He34), some essential properties relative to the speed function
 $\beta (t)$
are directly offered here without proof.
Lemma 3 Lemma 3 The speed function  $\beta (t)$
is a strictly increasing, bounded function in
 $t \in [0,\infty )$
satisfying the following properties with n = 3.
1)
 $\beta (0)\,=\,1$
,
$\beta (t)\,=\,1/{c_f}$
for
$t \ge T$
and
$\beta (t) \in \left[ {1,1/{c_f}} \right]$
for all
$t \ge 0$
.
2)
${\beta ^{(i)}}(t)(i\,=\,0,1, \ldots ,n)$
belong to the class
${C^{n - i}}$
function with respect to t and are bounded everywhere.3) For convenience, with
$\zeta (t) = {\beta ^{ - 1}}\dot{\beta} $
, it is easy to achieve the expression of
${\zeta ^{({\kern1.3pt}j)}}(t)({\kern1.3pt}j\,=\,0,1, \ldots ,n - 1)$
through mathematical methods. Moreover, we can obtain
${\zeta ^{({\kern1.3pt}j)}}$
, which belongs to the class
${C ^{n - 1 - j}}$
function of t and are bounded everywhere.


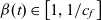

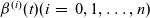


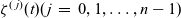


3.0 PROBLEM FORMULATION
3.1 Stratospheric airship model
The main structure of the stratospheric airship investigated herein contains a teardrop-shaped helium balloon, aerodynamic control surfaces, propellers, and an equipment tank, as exhibited in Fig. 1. The equipment tank is suspended from the body, whereas the rudders are attached to the empennage surfaces and provide steering torques. The propellers supply the primary propulsive forces for flight and are fixed on both sides of the equipment tank. Due to the existence of fans and valves, the airship can maintain a stable shape during operation. Thus, we consider the airship as a rigid body and neglect the aeroelastic effects. In this paper, we concentrate on the horizontal motions of the airship and assume that the airship is flying in a buoyancy-weight balance condition.
Sketch of the stratospheric airship.

To derive the kinematic and dynamic models of an airship, it is essential to define the coordinate systems as follows: An arbitrary point on the earth is chosen suitably as the origin of the earth reference frame (ERF), with x g pointing north and y g pointing east. The airship’s centre of volume (CV) is coincident with the origin of the body reference frame (BRF), with x b pointing forward and y b perpendicular to x b, pointing right. According to Zheng et al.(Reference Zheng, Guan, Ma and Zhu37), the horizontal motion of an airship can be modelled as
 \begin{equation}\left\{ \begin{array}{l} {\dot{\boldsymbol\eta} = \textbf{\textit{R}}(\psi )\boldsymbol\nu } \\[3pt] {\dot{\boldsymbol\nu} = \textbf{\textit{F}}(\boldsymbol\nu ) + {\textbf{\textit{M}}^{ - 1}}\boldsymbol\tau + \textbf{\textit{d}}} \end{array} \right.\end{equation}
 \begin{equation}\textbf{\textit{R}}(\psi ) = \left[ \begin{array}{c@{\quad}c@{\quad}c} {cos\psi } & { - sin\psi } & 0 \\[2pt] {sin\psi } & {cos\psi } & 0 \\[2pt] 0 & 0 & 1 \end{array} \right]\!,\quad \textbf{\textit{M}} = \left[ \begin{array}{c@{\quad}c@{\quad}c} {{m_u}} & 0 & 0 \\[2pt] 0 & {{m_v}} & 0 \\[2pt] 0 & 0 & {m_r} \\[2pt] \end{array} \right]\end{equation}
In Equations 7 and 8,  $\boldsymbol\eta = {[x,y,\psi ]^T}$
denotes the airship’s relative position and attitude under the ERF and
 $v = {[u,v,r]^T}$
represents linear velocities and yaw velocity under the BRF. M stands for the known inertia matrix, and
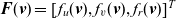 $\textbf{\textit{F}}(\textbf{\textit{v}}) = {[{{\kern1.3pt}f_u}(\textbf{\textit{v}}),{f_v}(\textbf{\textit{v}}),{f_r}(\textbf{\textit{v}})]^T}$
is an unknown nonlinear function vector, the components of which are forces and moments acting on the airship’s body caused by gravity, buoyancy, aerodynamic forces, Coriolis forces, and Coriolis torques. It should be noted that the airship is actuated in only two degrees of freedom (DOF). Thus, the airship is referred to as an underactuated system.
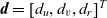 $\textbf{\textit{d}} = {[{d_u},{d_v},{d_r}]^T}$
indicates unknown environmental disturbances satisfying the following assumption.
Assumption 1 Assumption 1 The unknown external disturbances are bounded,(Reference Zheng, Guan, Ma and Zhu37) i.e., there exists an unknown positive constant  $\bar d$
such that
 $\left\| \textbf{\textit{d}} \right\| < \bar d$
.
3.2 Control objective
To explicitly clarify the control objective of this article, as illustrated in Fig. 2, the position tracking error E and attitude tracking error  ${\psi _e}$
are defined as
 \begin{align} {x_e} &= {x_d} - x,\ {y_e} = {y_d} - y \nonumber\\ \psi _e &= {\psi _r} - \psi,\ E = \sqrt{x_e^2 + y_e^2} \end{align}
where 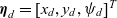 ${\boldsymbol{\eta}_d} = {[{x_d},{y_d},{\psi _d}]^T}$
denotes a desired time-varying trajectory and
 ${\psi _r} \in ( - \pi ,\pi ]$
is the desired azimuth angle of the airship, calculated by
 \begin{equation}{\psi _r} = arctan2[{{\kern1.3pt}y_e},{x_e})\end{equation}
In this paper, our goal is to develop a proper control scheme to steer the airship forward and track the horizontal reference trajectory with prescribed performance. Therefore, we give the following logical assumptions, which are quite helpful in the design of the control framework.
Assumption 2 Assumption 2  ${\boldsymbol\eta _d}$
and its derivatives up to
 ${\ddot{\boldsymbol\eta}_d}$
are all known and bounded.
Geometrical relationship for trajectory tracking.

Assumption 3 Assumption 3 The velocity  $\dot{\boldsymbol\eta}$
and acceleration
 $\ddot{\boldsymbol\eta}$
of the airship under the ERF are bounded(Reference Yu and Fu30). Furthermore, the sway velocity is passive-bounded(Reference Fu, Wang and Wang5).
Assumption 4 Assumption 4 The airship cruises at the bottom of the stratosphere and maintains a buoyancy-weight balance.
Remark 1 Remark 1 From Equation 10, it is evident that  ${\psi _r}$
is not well defined at E = 0; we define
 ${\psi _r} = {\psi _d}$
as E = 0 to resolve this potential control singularity problem.
Remark 2 Remark 2 In practical engineering, the magnitudes and rates of external forces and moments, disturbances, and control inputs acting on the airship body are all bounded. Moreover, we assume that the motion of the airship is a rigid body movement; thus, Assumption 3 is reasonable.
4.0 CONTROL ALGORITHM DESIGN
This section details the design process of the trajectory tracking control scheme with prescribed performance for the stratospheric airship. The controller consists of a surge motion control subsystem and a yaw motion control subsystem. Then, we conduct a theoretical analysis to demonstrate the stability of the proposed method.
4.1 Position control
This subsection focuses on computing the virtual control signal  $a_u^d$
to stabilise the position tracking error and calculating
 ${\tau _u}$
generated by the propellers for linear velocity tracking. To strictly guarantee the prescribed performance of position tracking, two error transformations are first defined as
 \begin{align} {\xi _E} &= \beta E \nonumber\\[3pt] {Z_E} &= {L_E}{\xi _E} \end{align}
where
 \begin{equation}{L_E} = \frac{1}{({k_{bE}} + {\xi _E})({k_{aE}} - {\xi _E})}\end{equation}
Note that the parameters  ${k_{aE}}\,>\,0$
and
 ${k_{bE}}\,>\,0$
are given by the operator, representing the asymmetric error constraints on E or
 ${\xi _E}$
. It is obvious that Z E is valid in the compact set
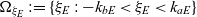 ${\Omega _{{\xi _E}}}: = \{ {\xi _E}:{-k_{bE}} < {\xi _E} < {k_{aE}}\} $
and for any
 \begin{equation} -\!{k_{bE}} < {\xi _E}(0) = E(0) < {k_{aE}}\end{equation}
if Z E is bounded for all  $t \ge 0$
and since
 $\beta $
is a monotone increasing function with respect to time, then the prescribed constraints are guaranteed, i.e.,
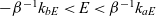 $ - {\beta ^{ - 1}}{k_{bE}} < E < {\beta ^{ - 1}}{k_{aE}}$
for all
 $t \ge 0$
and
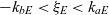 $ - {k_{bE}} < {\xi _E} < {k_{aE}}$
for all
 $t \ge 0$
. Then, calculating the derivative of E along the trajectories of Equation 7 yields
 \begin{equation}\dot{E} = {\dot{x}_d}cos{\psi _d} + {\dot{y}_d}sin{\psi _d} - ucos{\psi _e} - vsin{\psi _e}\end{equation}
Thus, we have the derivative of the transformed position tracking error Z E as
 \begin{equation}{\dot{Z}_E} = {\mu _E}\beta ({\beta ^{ - 1}}\dot{\beta} E + {\dot{x}_d}cos{\psi _d} + {\dot{y}_d}sin{\psi _d} - ucos{\psi _e} - vsin{\psi _e})\end{equation}
where
 \begin{equation}{\mu _E} = {\frac{{k_{aE}}{k_{bE}} + \xi _E^2}{{{({k_{bE}} + {\xi _E})}^2}{{({k_{aE}} - {\xi _E})}^2}}}\end{equation}
Since the velocity information of the airship is not measurable in real time and, specifically, at the current moment, to facilitate the design of the controller, an observer is constructed here to obtain exact velocity information. With the results in Ref. (Reference Yi, Wang and Li29), the nonlinear state observer is constructed as
 \begin{equation}\left\{ \begin{array}{l} {{{\dot{\boldsymbol\chi}}_1} = {\boldsymbol\chi_2} - {\boldsymbol{\lambda}_1}si{g^{{\boldsymbol\alpha_1}}}({\boldsymbol\chi _1} - \boldsymbol\eta )} \nonumber\\[3pt] {{{\dot{\boldsymbol\chi} }_2} = - {\boldsymbol\lambda_2}si{g^{{\boldsymbol\alpha_2}}}({\boldsymbol\chi _1} - {\boldsymbol\eta} )} \\ \end{array} \right.\end{equation}
where  ${\boldsymbol\lambda _1} = diag({\lambda _{1u}},{\lambda _{1v}},{\lambda _{1r}})$
and
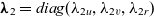 ${\boldsymbol\lambda_2} = diag({\lambda _{2u}},{\lambda _{2v}},{\lambda _{2r}})$
are positive definite coefficient matrices and
 ${\boldsymbol\alpha_1}$
and
 ${\boldsymbol\alpha_2}$
are design parameter vectors, described by
 \begin{align} & {\boldsymbol\alpha _1} = {[1 - 1/{p_u},1 - 1/{p_v},1 - 1/{p_r}]^T} \nonumber\\[3pt] & {\boldsymbol\alpha _2} = {[1 - 2/{p_u},1 - 2/{p_v},1 - 2/{p_r}]^T} \end{align}
With  ${p_i}\,>\,2$
,
 $i = u,v,r$
, and
 ${\boldsymbol\chi_1}$
and
 ${\boldsymbol\chi_2}$
are state vectors of the observer, denoting the estimations for
 $\boldsymbol\eta $
and
 $\dot{\boldsymbol\eta}$
, respectively. The observation errors are defined as
 \begin{align} & \tilde{\boldsymbol\eta} = \boldsymbol\eta - \hat{\boldsymbol\eta} \nonumber\\[3pt] & \tilde{\dot{\boldsymbol\eta}} = \dot{\boldsymbol\eta} - \hat{\dot{\boldsymbol\eta}} \end{align}
Clearly, by applying Lemma 1 and Assumption 3, an unknown positive constant  $\vartheta $
exists, such that
 \begin{equation}\left\| {\tilde{\dot{\boldsymbol\eta}}} \right\| \le \vartheta \end{equation}
Let us gain more insight into Equation 7. Utilising the fact that  $\left\| {\textbf{\textit{R}}(\psi )} \right\|\,=\,1$
, we can conclude that the estimation error
 $\tilde{v}$
is governed by
 $\vartheta $
, namely,
 \begin{equation}\left| {\tilde{v}} \right| \le {\vartheta _u} \le \left\| {\tilde{\textbf{\textit{v}}}} \right\| = \left\| {{\textbf{\textit{R}}^T}(\psi )(\dot{\boldsymbol{\eta}} - \hat{\dot{\boldsymbol{\eta}}} )} \right\| \le \vartheta \end{equation}
where  $\tilde{\textbf{\textit{v}}} = \textbf{\textit{v}} - \hat{\textbf{\textit{v}}}$
,
 $\tilde{v} = v - \hat{v}$
and
 ${\vartheta _u}$
denotes an unknown positive constant. From Equations 15 and 21, virtual control
 $a_u^d$
can be designed as
 \begin{align}a_u^d &= {(cos{\psi _e})^{ - 1}}({\beta ^{ - 1}}\dot{\beta} E + {\dot{x}_d}cos{\psi _d} + {\dot{y}_d}sin{\psi _d} - \hat{v}sin{\psi _e}) \nonumber\\[3pt] &\quad + {(cos{\psi _e})^{ - 1}}\left( {{k_E}\mu _E^{ - 1}{L_E}E + {\frac{{Z_E}{\mu _E}\beta }{2{\gamma _u}}} + {\frac{{Z_E}{\mu _E}\beta {{\hat{\vartheta} }_u}}{\sqrt {Z_E^2\mu _E^2{\beta ^2} + \Theta } }}} \right)\end{align}
where  ${k_E}\,>\,0$
,
 ${\gamma _u}\,>\,0$
, and
 $\Theta \,>\,0$
are design parameters and the update law for the estimate of
 ${\vartheta _u}$
is chosen as
 \vspace*{-3pt}\begin{equation}{\dot{\hat{\vartheta}}_u} = - {k_{\vartheta u}}{\hat{\vartheta} _u} + {\frac{Z_E^2\mu _E^2{\beta ^2}}{\sqrt {Z_E^2\mu _E^2{\beta ^2} + \Theta } }}\end{equation}
In this paper, we utilise the dynamic surface control method(Reference Swaroop, Hedrick, Yip and Gerdes23) to avoid complicated analytic differentiation of the virtual control  $a_u^d$
. The first-order filter can be expressed as
 \vspace*{-3pt}\begin{equation}{T_u}\dot{a}_u^c + a_u^c = a_u^d\end{equation}
where  ${T_u}\,>\,0$
denotes the time constant. To carry out recursive design, the surge speed tracking error and the filter error are defined as
 \vspace*{-3pt}\begin{align} {u_e} &= u - a_u^c \nonumber\\ {y_u} &= a_u^c - a_u^d \end{align}
Then, the derivative of y u is given by
 \vspace*{-3pt}\begin{align} {{{\dot{y}}_u}} & = \dot{a}_{.u}^c - \dot{a}_u^d \nonumber\\[3pt] & = - {\frac{{y_u}}{{T_u}}} + {B_u}({\psi _r},{{\dot{\psi} }_r},{{\dot{x}}_d},{{\ddot x}_d},{{\dot{y}}_d},{{\ddot y}_d},E,\dot{E},\beta ,\dot{\beta} ,\ddot \beta ,{\mu _E},{{\dot{\mu} }_E},{L_E},{{\dot{L}}_E},{Z_E},{{\dot{Z}}_E},{{\dot{\psi} }_e},{{\ddot \psi }_e},{{\hat{\vartheta} }_u},\hat{v},\dot{\hat{v}}) \end{align}
where  ${B_u}( \cdot )$
is a continuously bounded function on a compact set on a compact set(Reference Wang and Huang24)
 ${\Omega _{{y_u}}} \in {\mathbb{R}^{22}}$
, i.e.,
 $\left| {{B_u}( \cdot )} \right| < {M_u}$
with M u being an unknown positive constant. To facilitate a discussion of the design process, now consider the simple quadratic Lyapunov function candidate
 \vspace*{-3pt}\begin{equation}{V_E} = \frac{1}{2}Z_E^2 + \frac{1}{2}\tilde{\vartheta} _u^2 + \frac{1}{2}y_u^2\end{equation}
where  ${\tilde{\vartheta} _u} = {\vartheta _u} - {\hat{\vartheta} _u}$
. Taking the derivative of V E and using Equation 15, we obtain
 \begin{align}{\dot{V}_E} &= {Z_E}{\mu _E}\beta ({\beta ^{ - 1}}\dot{\beta} E + {\dot{x}_d}cos{\psi _d} + {\dot{y}_d}sin{\psi _d} - {u_e}cos{\psi _e} - {y_u}cos{\psi _e} - a_u^d - vsin{\psi _e}) + {y_u}{\dot{y}_u}\nonumber\\ &\quad - {\tilde{\vartheta} _u}{\dot{\hat{\vartheta}} _u}\end{align}
Substituting Equations 22, 23, and 26 into 28, and noting that the following inequalities hold:
 \begin{gather} - {Z_E}{\mu _E}\beta {y_u}cos{\psi _e} \le {{Z_E^2\mu _E^2{\beta ^2}} \over {2{\gamma _u}}} + {{{\gamma _u}y_u^2} \over 2} \nonumber\\[2pt] - {Z_E}{\mu _E}\beta \tilde{v}\textit{sin}{\psi _e} \le \left| {{Z_E}{\mu _E}\beta } \right|{\vartheta _u} \le \Theta {\vartheta _u} + {{Z_E^2\mu _E^2{\beta ^2}{\vartheta _u}} \over {\sqrt {Z_E^2\mu _E^2{\beta ^2} + \Theta } }} \nonumber\\[2pt] {{\tilde{\vartheta} }_u}{{\hat{\vartheta} }_u} \le - {{\tilde{\vartheta} _u^2} \over 2} + {{\vartheta _u^2} \over 2} \nonumber\\[2pt] {y_u}{B_u} \le {{y_u^2M_u^2} \over {4{b_u}}} + {b_u} \end{gather}
the derivative of V E can be given by
 \begin{equation}{\dot{V}_E} \le - {k_E}Z_E^2 - {{{k_{{\vartheta _u}}}\tilde{\vartheta} _u^2} \over 2} - \left( {{1 \over {{T_u}}} - {{M_u^2} \over {4{b_u}}} - {{{\gamma _u}} \over 2}} \right)y_u^2 - {Z_E}{\mu _E}\beta {u_e}\textit{cos} {\psi _e} + \Theta {\vartheta _u} + {{{k_{{\vartheta _u}}}\vartheta _u^2} \over 2} + {b_u}\end{equation}
Consider the surge speed dynamics in Equation 7; evaluating the derivative of u e gives
 \begin{equation}{\dot{u}_e} = {f_u}(\boldsymbol\nu ) + m_u^{ - 1}{\tau _u} + {d_u} - \dot{a}_u^c\end{equation}
It should be noted that the first equation in 7 can be rewritten as  $\boldsymbol\nu = {\textbf{\textit{R}}^T}(\psi )\dot{\boldsymbol\eta} $
; thus, the function
 ${f_u}(\boldsymbol\nu )$
can be restated as a continuous function
 ${f_u}(\boldsymbol\zeta )$
, where
 $\boldsymbol\zeta = {[{\boldsymbol\eta ^T},{\dot{\boldsymbol\eta} ^T}]^T}$
. Since the nonlinear
 ${f_u}(\boldsymbol\zeta )$
is indefinite, we use the RBF NNs to model the nonlinear functions
 ${f_u}(\boldsymbol\zeta )$
as(Reference Li, Tong, Liu and Feng13)
 \begin{align} {{\hat{f}}_u}(\hat{\boldsymbol\zeta} ) & = \hat{\textbf{\textit{W}}}_u^T{\boldsymbol{\phi}_u}(\hat{\boldsymbol\zeta} ) \nonumber\\[2pt] & = \left[ {{\hat{w}}_{u1}},\ {{\hat{w}}_{u2}},\ \ldots ,\ {{\hat{w}}_{uk}} \right]\left[ \begin{array}{c} {\phi _{u1}}(\hat{\boldsymbol\zeta} ) \\[3pt] {\phi _{u2}}(\hat{\boldsymbol\zeta} ) \\[3pt] \vdots \\[3pt] {\phi _{uk}}(\hat{\boldsymbol\zeta} ) \end{array}\right] \end{align}
Where  $\hat{\boldsymbol\zeta} = {\left[ {{{\hat{\boldsymbol\eta} }^T},{{\hat{\dot{\boldsymbol\eta}}}^T}} \right]^T}$
and
 ${\boldsymbol\phi _u}(\hat{\boldsymbol\zeta} )$
denotes the radial basis function vector with k being the number of nodes.
 ${\hat{\textbf{\textit{W}}}_u}$
is the estimation of the ideal weight vector
 $\textbf{\textit{W}}_u^*$
, which is computed by
 \begin{equation}\textbf{\textit{W}}_u^* = arg\,\mathop {min}\limits_{{{\hat{w}}_u} \in {\Omega _u}} \left\{ {\mathop {sup }\limits_{(\hat{\zeta} ,\zeta ) \in {\Xi _u}} \left| {{f_u}(\boldsymbol\zeta ) - \hat{\textbf{\textit{W}}}_u^T{\boldsymbol\phi _u}(\hat{{\boldsymbol\zeta}})} \right|} \right\}\end{equation}
Thus, the function  ${f_u}(\boldsymbol\zeta )$
can be expressed as
 \begin{equation}{f_u}(\boldsymbol\zeta ) = \textbf{\textit{W}}_u^{*T}{\boldsymbol\phi _u}(\hat{\boldsymbol\zeta} ) + {\epsilon _u}\end{equation}
Where  ${\epsilon _u}$
denotes the minimum approximation error satisfying
 $\left| {{\epsilon _u}} \right| < \epsilon _u^*$
, with
 $\epsilon _u^*$
being an unknown positive constant.
Therefore, the derivative of  ${u_e}$
can be rewritten as
 \begin{equation}{\dot{u}_e} = \textbf{\textit{W}}_u^{*T}{\boldsymbol\phi _u}(\hat{\boldsymbol\zeta} ) + m_u^{ - 1}{\tau _u} + {\delta _u} - \dot{a}_u^c\end{equation}
Note that the following inequality holds:
 \begin{equation}\left| {\textbf{\textit{W}}_u^{*T}{\boldsymbol\phi _u}(\hat{\boldsymbol\zeta} ) + {\delta _u}} \right| \le \left\| {\textbf{\textit{W}}_u^{*T}} \right\|\left\| {{\boldsymbol\phi _u}(\hat{\boldsymbol\zeta} )} \right\| + {\Delta _u} = {k_u}{\iota _u}\end{equation}
where 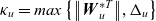 ${\kappa _u} = max\left\{ {\left\| {\textbf{\textit{W}}_u^{*T}} \right\|\!,{\Delta _u}} \right\}$
and
 ${\iota _u}\,=\,1 + \left\| {{\phi _u}} \right\|$
. Choosing the composite Lyapunov function for the position tracking control loop as
 \begin{equation}{V_P} = {V_E} + \frac{1}{2}u_e^2 + {1 \over {2{{\varpi}_u}}}\tilde{\Gamma} _u^2\end{equation}
where  ${\Gamma _u} = \kappa _u^2$
and
 ${\tilde{\Gamma} _u} = {\Gamma _u} - {\hat{\Gamma} _u}$
, we obtain
 \begin{equation}{\dot{V}_P} = {\dot{V}_E} + {u_e}(\textbf{\textit{W}}_u^{*T}{\boldsymbol\phi _u} + m_u^{ - 1}{\tau _u} + {\delta _u} - \dot{a}_u^c) - {1 \over {{{\varpi}_u}}}{\tilde{\Gamma} _u}{\dot{\hat{\Gamma}} _u}\end{equation}
Then, the control input command for surge velocity tracking and the adaptive law can be designed as
 \begin{equation}{\tau _u} = {m_u}\left( {\dot{a}_u^c - {k_u}{{\hat{u}}_e} + {Z_E}{\mu _E}\beta cos{\psi _e} - 2{{\hat{\Gamma} }_u}{\Phi _u}{{\hat{u}}_e}} \right)\end{equation}
 \begin{equation}\hspace*{-60pt}{\dot{\hat{\Gamma}} _u} = {\varpi _u}\left[ {{\Phi _u}\hat{u}_e^2 - {\sigma _u}({{\hat{\Gamma} }_u} - {{\hat{\Gamma} }_u}(0))} \right]\end{equation}
where  ${k_u}$
,
 ${\varpi _u}$
,
 ${\sigma _u}$
and
 ${\hat{\Gamma} _u}(0)$
are user-defined positive parameters,
 ${\hat{u}_e} = \hat{u} - a_u^c$
and
 ${\Phi _u} = \iota _u^2/2{c_u}$
, with
 ${c_u}\,>\,0$
. Based on the properties of RBF NNs, it should be clear that Φu has an unknown positive upper bound
 ${\Phi _{Mu}}$
, namely,
 $\left| {{\Phi _u}} \right| < {\Phi _{Mu}}$
. Using Young’s inequality, the following inequalities hold:
 \begin{align} {{{\tilde{\Gamma} }_u}{\Phi _u}u_e^2 - {{\tilde{\Gamma} }_u}{\Phi _u}\hat{u}_e^2} & {\,=\,2{{\tilde{\Gamma} }_u}{\Phi _u}{u_e}\tilde{u} - {{\tilde{\Gamma} }_u}{\Phi _u}{{\tilde{u}}^2}} \nonumber\\[2pt] & { \le 2\tilde{\Gamma} _u^2 + \Phi _{Mu}^2{\vartheta ^2}u_e^2 + {1 \over 4}\Phi _{Mu}^2{\vartheta ^4}} \nonumber\\[2pt] {{{\tilde{\Gamma} }_u}{\Phi _u}{{\tilde{u}}^2}} & { = {\Gamma _u}{\Phi _u}{{\tilde{u}}^2} - {{\tilde{\Gamma} }_u}{\Phi _u}{{\tilde{u}}^2}} \nonumber\\[2pt] {} & { \le ({\Gamma _u} + 1){\Phi _{Mu}}{\vartheta ^2} + {{{\Phi _{Mu}}{\vartheta ^2}} \over 4}\tilde{\Gamma} _u^2} \nonumber\\[2pt] {{\sigma _u}{{\tilde{\Gamma} }_u}({\Gamma _u} - {{\hat{\Gamma} }_u}(0))} & { \le {{{\sigma _u}} \over 2}\tilde{\Gamma} _u^2 + {{{\sigma _u}} \over 2}{{({\Gamma _u} - {{\hat{\Gamma} }_u}(0))}^2}} \end{align}
Using Equations 38, 39, and 40 and inequality 41 results in
 \begin{align} {{{\dot{V}}_P}} & = {{\dot{V}}_E} - {k_u}{{\hat{u}}_e}{u_e} + {u_e}(\textbf{\textit{W}}_u^{*T}{\boldsymbol\phi _u} + {\delta _u}) - 2{{\tilde{\Gamma} }_u}{\Phi _u}\hat{u}_{e} u_{e} - {{\tilde{\Gamma} }_u}{\Phi _u}\hat{u}_e^2\nonumber\\[2pt] &\quad + {\sigma _u}{{\tilde{\Gamma} }_u}({{\tilde{\Gamma} }_u} - {{\hat{\Gamma} }_u}(0)) + {Z_E}{\mu _E}\beta cos{\psi _e}{u_e} \nonumber\\[2pt] & \le {{\dot{V}}_E} - {k_u}u_e^2 + {k_u}{u_e}\tilde{u} + {\Gamma _u}{\Phi _u}u_e^2 - 2{{\hat{\Gamma} }_u}{\Phi _u}u_e^2 + 2{{\hat{\Gamma} }_u}{\Phi _u}{u_e}\tilde{u} \nonumber\\[3pt] & \quad - {{\tilde{\Gamma} }_u}{\Phi _u}\hat{u}_e^2 + {\sigma _u}{{\tilde{\Gamma} }_u}({{\hat{\Gamma} }_u} - {{\hat{\Gamma} }_u}(0)) + {Z_E}{\mu _E}\beta cos{\psi _e}{u_e} + {{{c_u}} \over 2} \nonumber\\[2pt] & \le {{\dot{V}}_E} - {{{k_u}} \over 2}u_e^2 + {{\tilde{\Gamma} }_u}{\Phi _u}u_e^2 + {{\hat{\Gamma} }_u}{\Phi _u}{{\tilde{u}}^2} - {{\tilde{\Gamma} }_u}{\Phi _u}\hat{u}_e^2 - {\sigma _u}\tilde{\Gamma} _u^2 \nonumber\\[2pt] &\quad + {\sigma _u}{{\tilde{\Gamma} }_u}({\Gamma _u} - {{\hat{\Gamma} }_u}(0)) + {Z_E}{\mu _E}\beta cos{\psi _e}{u_e} + {{{k_u}} \over 2}{\vartheta ^2} + {{{c_u}} \over 2} \nonumber\\[2pt] & \le {{\dot{V}}_E} - \left( {{{{k_u}} \over 2} - \Phi _{Mu}^2{\vartheta ^2}} \right)u_e^2 - \left( {{{{\sigma _u}} \over 2} - 2 - {1 \over 4}{\Phi _{Mu}}{\vartheta ^2}} \right)\tilde{\Gamma} _u^2 + {Z_E}{\mu _E}\beta cos{\psi _e}{u_e} \nonumber\\[2pt] &\quad + {\Phi _{Mu}}{\vartheta ^2}\left( {{\Gamma _u} + 1 + {1 \over 4}{\Phi _{Mu}}{\vartheta ^2}} \right) + {{{\sigma _u}} \over 2}{{({\Gamma _u} - {{\hat{\Gamma} }_u}(0))}^2} + {{{k_u}} \over 2}{\vartheta ^2} + {{{c_u}} \over 2} \end{align}
Substituting inequality 30 into 42, we obtain
 \begin{align} & {\dot{V}_P} \le - {k_E}Z_E^2 - {{{k_{\vartheta u}}\tilde{\vartheta} _u^2} \over 2} - \left( {{1 \over {{T_u}}} - {{M_u^2} \over {4{b_u}}} - {{{\gamma _u}} \over 2}} \right)y_u^2 - \left( {{{{k_u}} \over 2} - \Phi _{Mu}^2{\vartheta ^2}} \right)u_e^2 \nonumber\\[3pt] &\quad - \left( {{{{\sigma _u}} \over 2} - 2 - {1 \over 4}{\Phi _{Mu}}{\vartheta ^2}} \right){\tilde{\Gamma} ^2} + {\Game_u}\end{align}
where
 \begin{equation}{\Game_u} = \Theta {\vartheta _u} + {\Phi _{Mu}}{\vartheta ^2}\left( {{\Gamma _u} + 1 + {1 \over 4}{\Phi _{Mu}}{\vartheta ^2}} \right) + {{{\sigma _u}} \over 2}{\left( {{\Gamma _u} - {{\hat{\Gamma} }_u}(0)} \right)^2} + {{{k_u}} \over 2}{\vartheta ^2} + {{{k_{\vartheta u}}} \over 2}\vartheta _u^2 + {{{c_u}} \over 2} + {b_u}\end{equation}
The relevant conclusions in Equation 43 are needed for the stability analysis in subsection 4.3.
Remark 3 Remark 3 The purpose of the first error transformation in Equation 11 is to achieve position tracking incorporated with prescribed performance and that of the second is to meet the requirement of the position error constraint on E.
Remark 4 Remark 4 From Equations 12 and 16, we find that in the compact set 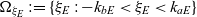 ${\Omega _{{\xi _E}}}: = \left\{ {{\xi _E}: - {k_{bE}} < {\xi _E} < {k_{aE}}} \right\}$
, both L E and
 ${\mu _E}$
are positive functions that can be calculated, implying that the two functions are available for the design of
 $a_u^d$
. From Equation 22, it follows that the stabilising function
 $a_u^d$
does not exist at
 ${\psi _e} = \pm \pi /2$
. Nevertheless, by confining
 ${\psi _e}$
to the compact set
 $ - 0.5\pi \le {k_{b{\psi _e}}} < {\psi _e} < {k_{b{\psi _e}}} \le 0.5\pi $
, which will be explained in detail later, the singularity problem will not occur.
Remark 5 Remark 5 To obtain minimal approximation error, we should provide sufficiently large NNs nodes. However, this will make the controller computationally expensive. As shown in Equation 36, we consider  ${\kappa _u}$
as an unknown scalar; hence, only two parameters need to be updated in the position tracking control loop regardless of the number of NNs nodes.
4.2 Attitude control
This subsection details the calculations of virtual control  $a_r^d$
to stabilise the attitude tracking error and
 ${\tau _r}$
generated by aerodynamic control surfaces for yaw velocity tracking. Similarly, the following error transformations are defined as
 \begin{align} {\xi _{{\psi _e}}} &= \beta {\psi _e} \nonumber\\ {Z_{{\psi _e}}} &= {L_{{\psi _e}}}{\xi _{{\psi _e}}} \end{align}
where
 \begin{equation}{L_{{\psi _e}}} = {1 \over {\left( {{k_{b{\psi _e}}} + {\xi _{{\psi _e}}}} \right)\left( {{k_{a{\psi _e}}} - {\xi _{{\psi _e}}}} \right)}}\end{equation}
In Equation 46,  ${k_{a{\psi _e}}}\,>\,0$
and
 ${k_{b{\psi _e}}}\,>\,0$
are user-defined parameters, standing for the asymmetric error constraints on
 ${\psi _e}$
or
 ${\xi _{{\psi _e}}}$
. Since the condition
 $\left| {{\psi _e}} \right|\,<\,0.5\pi $
should never be violated, the design parameters
 ${k_{a{\psi _e}}}$
and
 ${k_{b{\psi _e}}}$
should be selected appropriately such that
 \begin{equation} - 0.5\pi \le {k_{b{\psi _e}}} < {\xi _{{\psi _e}}}(0) = {\psi _e}(0) < {k_{a{\psi _e}}} \le 0.5\pi \end{equation}
The relevant analyses of the error transformations in Equation 45 are similar to the process applied to E and thus are omitted here. Following Equation 7, the derivative of  ${\psi _e}$
satisfies
 \begin{equation}{\dot{\psi} _e} = {\dot{\psi} _r} - r\end{equation}
Then, computing the derivative of  ${Z_{{\psi _e}}}$
results in
 \begin{equation}{\dot{Z}_{{\psi _e}}} = {\mu _{{\psi _e}}}\beta \left( {{\beta ^{ - 1}}\dot{\beta} {\psi _e} + {{\dot{\psi} }_r} - r} \right)\end{equation}
where
 \begin{align} {\mu _{{\psi _e}}} & = {{{k_{a{\psi _e}}}{k_{b{\psi _e}}} + \xi _{{\psi _e}}^2} \over {{{\left( {{k_{b{\psi _e}}} + {\xi _{{\psi _e}}}} \right)}^2}{{\left( {{k_{a{\psi _e}}} - {\xi _{{\psi _e}}}} \right)}^2}}} \nonumber\\[3pt] {{\dot{\psi} }_r} &= - {{\dot{x}}_d}{\jmath_y} + {{\dot{y}}_d}{\jmath_x} + \dot{x}{\jmath_y} - \dot{y}{\jmath_x} \end{align}
In Equation 50, 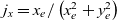 ${j_x} = {x_e}/\left( {x_e^2 + y_e^2} \right)$
and
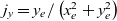 ${j_y} = {y_e}/\left( {x_e^2 + y_e^2} \right)$
. Since the estimation error
 $\tilde{\boldsymbol\nu} $
is uniformly bounded, we obtain
 \begin{equation}\left| {\tilde{\dot{x}}} \right| + \left| {\tilde{\dot{y}}} \right| \le {\vartheta _r}\end{equation}
Where  ${\vartheta _r}$
is an unknown positive constant. From Equations 49, 50, and 51, the virtual control
 $a_r^d$
and the update law are defined as
 \begin{equation}a_r^d = {\beta ^{ - 1}}\dot{\beta} {\psi _e} - {{\dot{x}}_d}{j_y} + {{\dot{y}}_d}{j_x} + \hat{\dot{x}}{j_y} - \dot{\hat{y}}{j_x} + {k_{{\psi _e}}}\mu _{{\psi _e}}^{ - 1}{L_{{\psi _e}}}{\psi _e} + {{{Z_{{\psi _e}}}{\mu _{{\psi _e}}}\beta } \over {2{\gamma _r}}} + {{{Z_{{\psi _e}}}{\mu _{{\psi _e}}}\beta {{\hat{\vartheta} }_r}} \over {\sqrt {Z_{{\psi _e}}^2\mu _{{\psi _e}}^2{\beta ^2} + \Theta } }}\end{equation}
 \begin{equation}{{\dot{\hat{\vartheta}} }_r} = - {k_{\vartheta r}}{{\hat{\vartheta} }_r} + {{Z_{{\psi _e}}^2\mu _{{\psi _e}}^2{\beta ^2}} \over {\sqrt {Z_{{\psi _e}}^2\mu _{{\psi _e}}^2{\beta ^2} + \Theta } }}\end{equation}
where  ${k_{{\psi _e}}}\,{>}\,0$
,
 ${\gamma _r}\,{>}\,0$
,
 $\Theta \,{>}\,0$
and
 ${k_{\vartheta r}}\,{>}\,0$
are design parameters. The following first-order filter is introduced to circumvent the problem of ‘explosion of complexity’ and generate
 $a_r^c$
and
 $\dot{a}_r^c$
:
 \begin{equation}{T_r}\dot{a}_r^c + a_r^c = a_r^d\end{equation}
where  ${T_r}\,>\,0$
represents the time constant, and the following three error variables are defined as:
 \begin{align} {r_e} &= r - a_r^c \nonumber\\ {{\hat{r}}_e} &= \hat{r} - a_r^c \nonumber\\ {y_r} &= a_r^c - a_r^d \end{align}
Taking the derivative of  ${y_r}$
gives
 \begin{align} {{\dot{y}}_r} &= \dot{a}_r^c - \dot{a}_r^d \nonumber\\ & = - {{{y_r}} \over {{T_r}}} + {B_r}\big( {\psi _e},{{\dot{\psi} }_e},\beta ,\dot{\beta} ,\ddot \beta ,{\mu _{{\psi _e}}},{{\dot{\mu} }_{{\psi _e}}},{L_{{\psi _e}}},{{\dot{L}}_{{\psi _e}}},{Z_{{\psi _e}}},{{\dot{Z}}_{{\psi _e}}},{x_e},{{\dot{x}}_e},{{\dot{x}}_d},{{\ddot x}_d},{y_e},{{\dot{y}}_e},{{\dot{y}}_d},{{\ddot y}_d},\hat{\dot{x}}, \nonumber\\[3pt] & \qquad \dot{\hat{\dot{x}}},\dot{\hat{y}},\dot{\dot{\hat{y}}} \big) \end{align}
where  ${B_r}( \cdot )$
is a continuous and bounded function on a compact set
 ${\Omega _{{y_r}}} \in \mathbb{R}{^{23}}$
, namely,
 ${\left| {{B_r}} \right| \le {M_r}}$
. According to the state-space Equation 7, the derivative of
 ${r_e}$
is given by
 \begin{equation}{\dot{r}_e} = {f_r}(\boldsymbol\nu ) + m_r^{ - 1}{\tau _r} + {d_r} - \dot{a}_r^c\end{equation}
Similarly, we still utilise RBF NNs to approximate the function  ${f_r}(\boldsymbol\nu )$
and employ the back-stepping techniques to achieve the control law. To avoid procedure design process descriptions, we directly give the results of the control input command
 ${\tau _r}$
and the update law
 ${\dot{\hat{\Gamma}} _r}$
, where all the variables have the same meaning as in the position tracking control loop. Then, the control input command
 ${\tau _r}$
and the adaptive law
 ${\dot{\hat{\Gamma}} _r}$
are developed in the following forms:
 \begin{equation}{\tau _r} = {m_r}\left( {\dot{a}_r^c - {k_r}{{\hat{r}}_e} + {Z_{{\psi _e}}}{\mu _{{\psi _e}}}\beta - 2{{\hat{\Gamma} }_r}{\Phi _r}{{\hat{r}}_e}} \right)\end{equation}
 \begin{equation}{\dot{\hat{\Gamma}} _r} = {\varpi _r}\left( {{\Phi _r}\hat{r}_e^2 - {\sigma _r}\left[ {{{\hat{\Gamma} }_r} - {{\hat{\Gamma} }_r}(0)} \right]} \right)\end{equation}
where  ${k_r}$
,
 ${\varpi _r}$
,
 ${\sigma _r}$
and
 ${\hat{\Gamma} _r}(0)$
are positive design constants and
 $\left| {{\Phi _r}} \right| \le {\Phi _{Mr}}$
with
 ${\Phi _{Mr}}$
being an unknown positive constant. For the attitude tracking control loop, if we choose the Lyapunov candidate function to be
 \begin{equation}{V_A} = \frac{1}{2}Z_{{\psi _2}}^2 + \frac{1}{2}\tilde{\vartheta} _r^2 + \frac{1}{2}y_r^2 + \frac{1}{2}r_e^2 + \frac{1}{2{\varpi _r}}\tilde{\Gamma} _r^2\end{equation}
then computing the first-order derivative of V A and using Equations 49 and 55 gives
 \begin{equation}{\dot{V}_A} = {Z_{{\psi _e}}}{\mu _{{\psi _e}}}\beta \left( {{\beta ^{ - 1}}\dot{\beta} {\psi _e} + {{\dot{\psi} }_r} - {r_e} - {y_r} - a_r^d} \right) - {\tilde{\vartheta} _r}{\dot{\hat{\vartheta}} _r} + {y_r}{\dot{y}_r} + {r_e}{\dot{r}_e} - \frac{1}{{\varpi _r}}{\tilde{\Gamma} _r}{\dot{\hat{\Gamma}} _r}\end{equation}
Substituting Equations 52, 53, 56, 57, 58 and 59 into 61 and considering the following inequalities
 \begin{align} {Z_{{\psi _e}}}{\mu _{{\psi _e}}}\beta \left( {\tilde{\dot{x}}.{\jmath_y} - \tilde{\dot{y}}.{\jmath_x}} \right) & \le |{Z_{{\psi _e}}}{\mu _{{\psi _e}}}\beta |{\vartheta _r} \le \Theta {\vartheta _r} + {\frac{Z_{{\psi _e}}^2\mu _{{\psi _e}}^2{\beta ^2}{\vartheta _r}}{\sqrt {Z_{{\psi _e}}^2\mu _{{\psi _e}}^2{\beta ^2} + \Theta } }} \nonumber\\
- {Z_{{\psi _e}}}{\mu _{{\psi _e}}}\beta {y_r} & \le {\frac{Z_{{\psi _e}}^2\mu _{{\psi _e}}^2{\beta ^2}}{2{\gamma _r}}} + \frac{{\gamma _r}\gamma _r^2}{2} \nonumber\\
{{\tilde{\vartheta} }_r}{{\hat{\vartheta} }_r} & \le \frac{\tilde{\vartheta} _r^2}{2} + \frac{\vartheta _r^2}{2} \nonumber\\
{y_r}{B_r} & \le {\frac{y_r^2M_r^2}{4{b_r}}} + {b_r} \nonumber\displaybreak\\
{{\tilde{\Gamma} }_r}{\Phi _r}r_e^2 - {{\tilde{\Gamma} }_r}{\Phi _r}\hat{r}_e^2 & = 2{{\tilde{\Gamma} }_r}{\Phi _r}{r_e}\tilde{r} - {{\tilde{\Gamma} }_r}{\Phi _r}{{\tilde{r}}^2} \le 2\tilde{\Gamma} _r^2 + \Phi _{Mr}^2{\vartheta ^2}r_e^2 + \frac{1}{4}\Phi _{Mr}^2{\vartheta ^4} \nonumber\\
{{\tilde{\Gamma} }_r}{\Phi _r}{{\tilde{r}}^2} & = {\Gamma _r}{\Phi _r}{{\tilde{r}}^2} - {{\tilde{\Gamma} }_r}{\Phi _r}{{\tilde{r}}^2} \le ({\Gamma _r} + 1){\Phi _{Mr}}{\vartheta ^2} + \frac{{\Phi _{Mr}}{\vartheta ^2}}{4}\tilde{\Gamma} _r^2 \nonumber\\
{\sigma _r}{{\tilde{\Gamma} }_r}\left( {{\Gamma _r} - {{\hat{\Gamma} }_r}(0)} \right) & \le {{{\sigma _r}} \over 2}\tilde{\Gamma} _r^2 + {{{\sigma _r}} \over 2}{{\left( {{\Gamma _r} - {{\hat{\Gamma} }_r}(0)} \right)}^2}\end{align}
we thus arrive at
 \begin{align} {{\dot{V}}_{{\psi _e}}} &\le - {k_{{\psi _e}}}Z_{{\psi _e}}^2 - {{{k_{\vartheta r}}\tilde{\vartheta} _r^2} \over 2} - \left( {{1 \over {{T_r}}} - {{M_r^2} \over {4{b_r}}} - {{{\gamma _r}} \over 2}} \right)y_r^2 - {k_r}{{\hat{r}}_e}{r_e} + {r_e}\left( {W_r^{*T}{\phi _r} + {\delta _r}} \right) \nonumber\\
&\quad - 2{{\hat{\Gamma} }_r}{\Phi _r}{{\hat{r}}_e}{r_e} - {{\tilde{\Gamma} }_r}{\Phi _r}\hat{r}_e^2 + {\sigma _r}{{\tilde{\Gamma} }_r}\left[ {{{\hat{\Gamma} }_r} - {{\hat{\Gamma} }_r}(0)} \right] + \Theta {\vartheta _r} + {{{k_{\vartheta r}}\vartheta _r^2} \over 2} + {b_u} \nonumber\\
&\le - {k_{{\psi _e}}}Z_{{\psi _e}}^2 - {{{k_{\vartheta r}}\tilde{\vartheta} _r^2} \over 2} - \left( {{1 \over {{T_r}}} - {{M_r^2} \over {4{b_r}}} - {{{\gamma _r}} \over 2}} \right)y_r^2 - {k_r}r_e^2 + {k_r}{r_e}\tilde{r} + {\Gamma _r}{\Phi _r}r_e^2 - {{\tilde{\Gamma} }_r}{\Phi _r}\hat{r}_e^2 \nonumber\\
&\quad - 2{{\hat{\Gamma} }_r}{\Phi _r}r_e^2 + 2{{\hat{\Gamma} }_r}{\Phi _r}{r_e}\tilde{r} + {\sigma _r}{{\tilde{\Gamma} }_r}\left[ {{{\hat{\Gamma} }_r} - {{\hat{\Gamma} }_r}(0)} \right] + \Theta {\vartheta _r} + {{{k_{\vartheta r}}\vartheta _r^2} \over 2} + {b_u} + {{{c_r}} \over 2} \nonumber\\
& \le - {k_{{\psi _e}}}Z_{{\psi _e}}^2 - {{{k_{\vartheta r}}\tilde{\vartheta} _r^2} \over 2} - \left( {{1 \over {{T_r}}} - {{M_r^2} \over {4{b_r}}} - {{{\gamma _r}} \over 2}} \right)y_r^2 - \left( {{{{k_r}} \over 2} - \Phi _{Mr}^2{\vartheta ^2}} \right)r_e^2 \nonumber\\
&\quad - \left( {{{{\sigma _r}} \over 2} - 2 - {1 \over 4}{\Phi _{Mr}}{\vartheta ^2}} \right)\tilde{\Gamma} _r^2 + {\Game_r} \end{align}
where
 \begin{equation}{\Game_r} = {\Phi _{Mr}}{\vartheta ^2}\left( {{\Gamma _r} + 1 + {1 \over 4}{\Phi _{Mr}}{\vartheta ^2}} \right) + {{{\sigma _r}} \over 2}{\left( {{\Gamma _r} - {{\hat{\Gamma} }_r}(0)} \right)^2} + {{{k_r}} \over 2}{\vartheta ^2} + {{{k_{\vartheta r}}} \over 2}\vartheta _r^2 + {{{c_r}} \over 2} + \Theta {\vartheta _r} + {b_r}\end{equation}
The conclusions in Equation 63 are also needed for stability analysis of the controller in subsection 4.3.
4.3 Stability analysis
The properties of the proposed trajectory tracking control algorithm are summarised in the next theorem.
Theorem 1 Theorem 1 Consider the stratospheric airship model 7 subject to model uncertainties and disturbances, with the actual controllers 39 and 58, the adaptive laws 23, 40, 53, and 59 and the observer 17. Suppose that Assumptions 1–4 hold; if  ${k_{ai}}$
and
 ${k_{bi}}$
,
 $i = E,{\psi _e}$
, are selected appropriately such that
 $ - {k_{bE}} < {\xi _E}\!\left( 0 \right) = E\!\left( 0 \right) < {k_{aE}}$
and
 $ - {k_{b{\psi _e}}} < {\xi _{{\psi _e}}}\!\left( 0 \right) = {\psi _e}\!\left( 0 \right) < {k_{a{\psi _e}}}$
and if other gain parameters satisfy 67, then the following holds:
1) All signals in the closed-loop system are uniformly bounded.
2) The transient and steady tracking performance can be stipulated quantitatively, i.e., the tracking errors are guaranteed to enter prescribed compact sets before a preset finite time T with decay rates no less than a preassigned value and remain so on all future compact sets. Meanwhile, the constraints on the tracking errors are not violated during operation, i.e.,
$ - {k_{bE}} < E < {k_{aE}}$
and
$ - {k_{b{\psi _e}}} < {\psi _e} < {k_{a{\psi _e}}}$
,
$\forall t \ge 0$
.
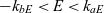
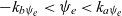

Proof. Assign the complete Lyapunov function candidate as
 \begin{equation}V = {V_P} + {V_A}\end{equation}
Given Equations 43 and 63, the time derivative of V satisfies
 \begin{align} \dot{V} &\le - {k_E}Z_E^2 - {k_{{\psi _e}}}Z_{{\psi _e}}^2 - {{{k_{\vartheta u}}\tilde{\vartheta} _u^2} \over 2} - {{{k_{\vartheta r}}\tilde{\vartheta} _r^2} \over 2} - \left( {{{{k_u}} \over 2} - \Phi _{Mu}^2{\vartheta ^2}} \right)u_e^2 \nonumber\\
&\quad - \left( {{{{k_r}} \over 2} - \Phi _{Mr}^2{\vartheta ^2}} \right)r_e^2 - \left( {{1 \over {{T_u}}} - {{M_u^2} \over {4{b_u}}} - {{{\gamma _E}} \over 2}} \right)y_u^2 - \left( {{1 \over {{T_r}}} - {{M_r^2} \over {4{b_r}}} - {{{\gamma _\psi }} \over 2}} \right)y_r^2 \nonumber\\
&\quad - \left( {{{{\sigma _u}} \over 2} - 2 - {1 \over 4}{\Phi _{Mu}}{\vartheta ^2}} \right)\tilde{\Gamma} _u^2 - \left( {{{{\sigma _r}} \over 2} - 2 - {1 \over 4}{\Phi _{Mr}}{\vartheta ^2}} \right)\tilde{\Gamma} _r^2 + \Game \end{align}
where  $ \Game= {\Game_u} + {\Game_r}$
. Choosing appropriate design parameters such that
 \begin{align} &{{{k_i}} \over 2} - \Phi _{Mi}^2{\vartheta ^2} \ge 0 \nonumber\\[2pt]
&{{{\sigma _i}} \over 2} - 2 - {1 \over 4}{\Phi _{Mi}}{\vartheta ^2} \ge 0 \nonumber\\[2pt]
&{1 \over {{T_i}}} - {{M_i^2} \over {4{b_i}}} - {{{\gamma _i}} \over 2} \ge 0 \end{align}
where  $i = u,r$
, inequality 66 can be rewritten as
 \begin{equation}\dot{V} \le - \ell V + \Game\end{equation}
Where 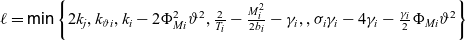 $\ell = \textsf{min} \left\{ {2{k_j},{k_{\vartheta i}},{k_i} - 2\Phi _{Mi}^2{\vartheta ^2},\frac{2}{{{T_i}}} - \frac{{M_i^2}}{{2{b_i}}} - {\gamma _i},,{\sigma _i}{\gamma _i} - 4{\gamma _i} - \frac{{{\gamma _i}}}{2}{\Phi _{Mi}}{\vartheta ^2}} \right\}$
with
 $i = u,r$
,
 $j = E,{\psi _e}$
.
Integrating both sides of inequality 68 results in
 \begin{equation}0 \le V\left( t \right) \le {\Game \over \ell } + \left( {V\!\left( 0 \right) - {\Game \over \ell }} \right){e^{ - \ell t}}\end{equation}
Consequently, it is evident that the signals  ${Z_E}$
,
 ${Z_{{\psi _e}}}$
,
 ${\tilde{\vartheta} _u}$
,
 ${\tilde{\vartheta} _r}$
,
 ${u_e}$
,
 ${r_e}$
,
 ${y_u}$
,
 ${y_r}$
,
 ${\tilde{\Gamma} _u}$
and
 ${\tilde{\Gamma} _r}$
are all semi-globally uniformly ultimately bounded. Therefore, all the signals in the loop system are uniformly bounded.
It should be highlighted that tracking error  ${Z_i}\left( {i = E,{\psi _e}} \right)$
being bounded for all
 $t \ge 0$
implies that
 ${\xi _i}\left( {i = E,{\psi _e}} \right)$
always remains in the compact set
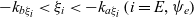 $ - {k_{b{\xi _i}}} < {\xi _i} < - {k_{a{\xi _i}}}\left( {i = E,{\psi _e}} \right)$
as long as the initial conditions stated in Equations 13 and 47 are satisfied, which further indicates that the tracking-error-constrained requirements are not violated, i.e.,
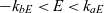 $ - {k_{bE}} < E < {k_{aE}}$
and
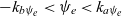 $ - {k_{b{\psi _e}}} < {\psi _e} < {k_{a{\psi _e}}}$
,
 $\forall t \ge 0$
.
Airship simulation parameters

According to  ${\xi _E} = \beta E$
and noting that
 ${\xi _E}$
is confined to the set
 $ - {k_{b{\xi _E}}} < {\xi _E} < - {k_{a{\xi _E}}}$
all the time, the following inequalities hold:
 \begin{align}\left\{ \begin{array}{ll} - \left( {1 - {c_f}} \right){{\left( {\frac{{T - t}}{T}} \right)}^4}{e^{ - t}}{k_{bE}} - {c_f}{k_{bE}}&\\[2pt] \qquad\quad < E < & ,0 \le t < T \\[2pt] \left( {1 - {c_f}} \right){{\left( {\frac{{T - t}}{T}} \right)}^4}{e^{ - t}}{k_{aE}} + {c_f}{k_{aE}}& \\[2pt] - {c_f}{k_{bE}} < E < {c_f}{k_{aE}}&,t \ge T \end{array}\right. \end{align}
where 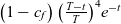 $\left( {1 - {c_f}} \right){\left( {\frac{{T - t}}{T}} \right)^4}{e^{ - t}}$
represents a preassigned convergence rate. From Equations 69 and 70, we understand that the convergence rate of position error E is not only ruled by T and c f but also influenced by parameter
 $\ell$
. By adjusting the design parameters, we can make the error convergence rate greater than
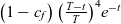 $\left( {1 - {c_f}} \right){\left( {\frac{{T - t}}{T}} \right)^4}{e^{ - t}}$
. However, regardless of the final value of parameter
 $\ell$
, the error convergence rate will not be less than
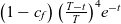 $\left( {1 - {c_f}} \right){\left( {\frac{{T - t}}{T}} \right)^4}{e^{ - t}}$
, which signifies the main merit of this controller. Moreover, Equation 70 reveals that the proposed control scheme ensures that the tracking error E converges to the prescribed compact set
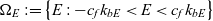 ${\Omega _E}: = \left\{ {E: - {c_f}{k_{bE}} < E < {c_f}{k_{bE}}} \right\}$
within a finite time T. Adopting a similar reasoning process, we can also reach the same conclusion for
 ${\psi _e}$
. Thus, Theorem 1 is proved.
Remark 6 Remark 6 Unlike most current control schemes, to properly determine the design parameters such that 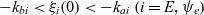 $ - {k_{bi}} < {\xi _i}\!\left( 0 \right) < - {k_{ai}}\left( {i = E,{\psi _e}} \right)$
, the exact initial position and yaw angle of the airship are necessary. Here, we only need some rough information. Because even if
 ${k_{bi}}$
and
 ${k_{ai}}\left( {i = E,{\psi _e}} \right)$
are chosen such that they are relatively large, if a small value of the free design parameter
 ${c_f}$
is chosen, the adverse effect of the large value on the error accuracy can be easily offset.
Trajectory of the airship.

Trajectory tracking errors.

5.0 SIMULATION STUDY
To confirm the effectiveness of the presented control strategy, a numerical example of horizontal trajectory tracking is considered with the help of MATLAB software. We apply trajectory tracking controller to the 3-degree-of-freedom stratospheric airship model given by Equation 7 and reach some conclusions, delineated by the following pictures. The kinematics, dynamics, and physical parameters for the airship are from Ref. (Reference Zheng, Guan, Ma and Zhu37); therefore, the unknown nonlinear functions,  ${f_u}(\boldsymbol{\nu })$
,
 ${f_v}(\boldsymbol{\nu })$
and
 ${f_r}(\boldsymbol{\nu })$
in Equation 7 can be given by
 \begin{equation}\left\{ \begin{array}{l}{f_u}(\boldsymbol{\nu }) = \left( {{m_v}vr - {d_u}u} \right)/{m_u}\\[2pt] {f_v}(\boldsymbol{\nu }) = \left( { - {m_u}ur - {d_v}v} \right)/{m_v}\\[2pt] {f_r}(\boldsymbol{\nu }) = \left[ {\left( {{m_u} - {m_v}} \right)uv - {d_r}r} \right]/{m_r}\end{array} \right.\end{equation}
and the external disturbances are chosen as
 \begin{equation}\left\{ {\begin{array}{*{20}{c}}{{d_u} = \left( {1.5 + 0.2 \times \textsf{sin}\; t + 0.3 \times \textsf{cos}\; t} \right) \times 0.02}\\[2pt] {{d_v} = \left( {1.5 + 0.2 \times \textsf{sin}\; t + 0.3 \times \textsf{cos}\; t} \right) \times 0.01}\\[2pt] {{d_r} = - (1.5 + 0.1 \times \textsf{sin}\; t + 0.2 \times \textsf{cos}\; t) \times 0.1}\end{array}} \right.\end{equation}
Observer errors.

Forward speed and yaw speed.

In this article, we select a challenging S-curve reference trajectory for the simulation. The initial states of the reference trajectory are  $\left[ {0m,0m,0rad} \right]$
. The desired surge and transverse velocities are set as
 ${u_d}\,=\,1m/s$
and
 ${v_d}\,=\,0m/s$
, respectively, and the desired yaw velocity
 ${r_d}$
is described by the following equation:
 \begin{equation}\left\{ {\begin{array}{*{20}{l}}{{r_d}\,=\,21 \times t \times {{10}^{ - 4}}}, &\quad {0 \le t < 50}\\{{r_d}\,=\,0}, &\quad {50 \le t < 70}\\{{r_d}\,=\,21 \times \left( {t - 120} \right) \times {{10}^{ - 4}}}, &\quad {t \ge 70}\end{array}} \right.\end{equation}
The initial states of the real airship are  $\left[ {x(0),y(0),\psi (0)} \right] = \left[ { - 1.5m, - 1m,0.588rad} \right]$
, and the initial velocities of the airship are
 $\left[ {u(0),v(0),r(0)} \right] = \left[ {0{m \mathord{\left/{\vphantom {m s}} \right. \kern-\nulldelimiterspace} s},0{m \mathord{\left/{\vphantom {m s}} \right.\kern-\nulldelimiterspace} s},0{{rad} \mathord{\left/{\vphantom {{rad} s}} \right.\kern-\nulldelimiterspace} s}} \right]$
. The properties of the designed RBF NNs are as follows: 41 hidden nodes provided for each item of
 ${f_u}(\boldsymbol{\nu })$
and
 ${f_r}(\boldsymbol{\nu })$
, centre
 ${p_u}$
and
 ${p_r}$
evenly spaced in the area
 $\left[ { - 2,2} \right] \times \left[ { - 2,2} \right] \times \left[ { - 2,2} \right]$
, and spread
 ${q_u}\,=\,2$
and
 ${q_r}\,=\,2$
.
Control inputs.

Tracking errors with different parameters cf.

All design parameters required for the simulation are listed in Table 1. The simulation results regarding the positions, trajectory tracking errors, observer errors, velocities, and control inputs are illustrated in Figs. 3−7.
Tracking errors with different parameters T.

Trajectory under different methods.

From Fig. 3, we can discern that the airship can approach the reference trajectory swiftly and smoothly. Then, the airship tracks the reference trajectory with high accuracy, even if there are corners in this reference trajectory. Neither the position tracking error E or attitude tracking error  ${\psi _e}$
exceeds the specified constraints, as depicted in Fig. 4.
It is worth noting that both E and  ${\psi _e}$
can converge to the prescribed convergence domains
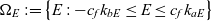 ${\Omega _E}: = \left\{ {E: - {c_f}{k_{bE}} \le E \le {c_f}{k_{aE}}} \right\}$
and
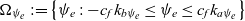 ${\Omega _{{\psi _e}}}: = \left\{ {{\psi _e}: - {c_f}{k_{b{\psi _e}}} \le {\psi _e} \le {c_f}{k_{a{\psi _e}}}} \right\}$
within the preselected settling time T = 4s and stay in small, reasonable residual sets around zero, respectively. Thus, the controller proposed in this article can warrant that the airship has a specified transient and steady-state tracking behaviour, and we achieve the control goals stated in Section 3.0. Figure 5 confirms the effectiveness of the observer formed in this paper, where the observer errors rapidly approach zero and Figs. 6 and 7 demonstrate the time histories of velocities and control inputs, respectively.
To attest that the speed equation  $\beta (t)$
has an essential influence on the tracking performance, we chose different design parameters, T and
 ${c_f}$
, for simulation. The simulation results prove that the settling time T plays a significant role in the transient process and that the design parameter
 ${c_f}$
can cause different steady-state errors, which are shown in Figs. 8 and 9.
Subsequently, to affirm that the control scheme proposed herein has a much better control performance, we conducted comparison simulations using the standard back-stepping methodology offered by Repoulias et al.(Reference Repoulias and Papadopoulos19). For a straightforward comparison, the initial position, attitude, velocities of the airship, and the reference trajectory are identical to those in the preceding example. Figures 10 and 11 depict the comparison results. Under the control scheme(Reference Repoulias and Papadopoulos19), the tracking performance was not unsatisfactory, whereas the controller proposed in this paper can guarantee high-precision trajectory tracking. Consequently, based on the above analysis, we declare that the control method can guarantee the essential dynamic and steady performance, which is mainly due to the speed equation and error transformations.
Tracking errors under different methods.

6.0 CONCLUSIONS
This paper presents a neuroadaptive output-feedback control scheme to actualise horizontal trajectory tracking for a stratospheric airship. An FTCO was employed to obtain the immeasurable velocity information. To design the controller with prescribed performance, we integrated a speed function and error transformations into the design process such that the tracking errors converged to the specified residual boundaries before a pre-chosen finite time with decay rates no less than an assignable value. Moreover, we combined RBF NNs control with MLP techniques to solve unknown items in the model and alleviated the computational burden concurrently. Lyapunov analysis proved that the control framework presented guaranteed the uniform boundedness of all the signals within the closed-loop system. The simulations confirmed the effectiveness and robustness of the proposed control structure. We will include trajectory tracking with thermal issues and actuator failures in our future work.
ACKNOWLEDGEMENTS
This work was supported in part by the National Natural Science Foundation of China under Grant Nos. 51205253 and 51906141.



