


1. Introduction
The multi-agent pursuit-evasion game [Reference Ramana and Kothari1–Reference Cristino de Souza, Newbury, Cosgun, Castillo, Vidolov and Kulić3] mainly considers the confrontation between two groups of agents, where one group of agents, namely pursuers, attempt to act as a team to cooperatively pursue another group of agents, namely evaders. The target-attacker-defender (TAD) game is a more complex game based on the pursuit-evasion game, consisting of two simultaneous sets of pursuit-evasion game: the attacker-target and the defender-attacker. Particular interest has been received in numerous military and civil fields, such as formation patrolling [Reference Asai and Sakurama4], attack and defense confrontation [Reference Pierson, Ataei, Paschalidis and Schwager5, Reference Harel, Moshaiov and Alkaher6], spacecraft pursuit-evasion [Reference Gong, Gong and Li7, Reference Zeng, Yang, Zhu and Yang8], territorial defense [Reference Deng and Kong9, Reference Shishika, Paulos and Kumar10], missile tracking, and interception [Reference Shalumov11–Reference Jana, Tony, Bhise, Varun and Ghose13].
The target in a TAD game could be static or dynamic, and a point, an edge, or a region. Yan et al. [Reference Yan, Shi and Zhong14–Reference Yan, Deng, Lai, Zhang, Shi and Zhong17] investigated the so-called reach-avoid game comprehensively, where the target is a static edge in two-dimensional environment or a static goal region in three-dimensional environment. For the case of dynamic target, Manoharan et al. [Reference Manoharan and Baliyarasimhuni18] proposed a nonlinear model predictive control-based framework to deal with the three-agent TAD game, where the target-defender team acts in a cooperative manner and an extended Kalman filter is adopted to estimate the states of the attacker. Moreover, the games with two-target two-attacker [Reference Manoharan and Sujit19] and multi-defender multi-attacker [Reference Manoharan, Thakur and Singh20] are also investigated in depth.
Garcia et al. have conducted a series of studies on TAD issues from the perspective of quantitative differential games. Pachter et al. [Reference Pachter, Garcia and Casbeer21] proposed a defense strategy for the defenders assuming that the direction of the attacker’s motion is known. Garcia et al. [Reference Garcia, Casbeer and Pachter22–Reference Garcia, Casbeer and Pachter24] analyzed the optimal strategies for the target and defender when the attacker adopts a pure pursuit strategy, proportional guidance strategy, or strategy of differential games. Further research has been conducted. Considering the speed of the defender, the turning speed has an upper limit [Reference Casbeer, Garcia, Fuchs and Pachter25], or it is greater than the attacker [Reference Garcia, Casbeer and Pachter26]. Furthermore, the active target defense is extended in three-dimensional space [Reference Weintraub, Garcia and Pachter27], and the impact on the reachable regions of each agent caused by the capture distance is analyzed [Reference Garcia28]. In the aforementioned literature, the terminal distance between the attacker and the target or between the attacker and the defender is often taken as the optimization objective, and then the optimal motion strategy of each agent is obtained by establishing and solving the Hamiltonian equation.
Liang et al. [Reference Liang, Peng, Zhang and Li29] analyzed the TAD problem according to the qualitative differential games. The Apollonius circle is utilized to construct a barrier to divide the state space into three regions: the winning region of the attacker, the winning region of the target-defender, and the uncertain region. Then, a cost function is established to solve out the optimal strategy of each agent in different regions. On this basis, the effects on the barrier caused by the speed ratio between different agents and the numbers of defenders are studied [Reference Liang, Deng, Peng, Li and Zha30–Reference Liang and Deng32]. In addition, the cooperation and confrontation strategies have also been considered where the defender’s activity area is restricted [Reference Liang, Deng, Shi and Lu33, Reference Liang, Deng, Wang, Lu and Chen34]. However, it is assumed that the heading information of each agent is timely known and accurate, which may not be feasible in practical scenario.
From the perspective of practical application, Shaferman et al. [Reference Shaferman and Shima35] proposed a collaborative guidance law for a defense missile to protect the target against the incoming homing missile, where a multiple model adaptive estimator is introduced to identify the guidance law and parameters of the incoming missile. From the perspective of pursuit-evasion differential games, Shima [Reference Shima36] analyzed the optimal strategies for the target and defender when the incoming missile employs different guidance laws. Kumar et al. [Reference Kumar and Shima37] tackled the target defense problem with large heading errors by combining line-of-sight-based guidance law with sliding mode control, where the normal accelerations of the defender and the target are considered as control input for the guidance system. Though the above strategies are effective in various complex environments, it should be noted that directly measuring the acceleration poses challenges in practical application.
This paper focuses on the cooperative defense in a TAD game with position information only. In most applications, the target needs to be defended mainly caused by its limited maneuverability or territorial constrain. Thus, a low-speed territorial-constrained target is considered. In order to defend the target as well as capture the attacker, multiple defenders should behave in a cooperative manner. Considering the fact in some attack and defense confrontation circumstances that the defender should not threaten the target, that is, the strategy where the target and defender converge to conclude the game is not considered. As a shared player in the two simultaneous pursuit-evasion games, both capturing the target and escaping from the defender are considered as objectives of the attacker, which is not available to the defender and the target. The main contributions of this paper can be summarized as follows: (1) an annular area is defined for the territorial-constrained target, then the motion strategy of the target is derived respectively in three different cases based on the initial distribution of the players; (2) according to the position information of all players, the defenders are classified as primary defender and auxiliary defenders, where the primary defender is mainly for defending the target and auxiliary defenders are for capturing the attacker timely; and (3) a weighted defense strategy is proposed based on the intention prediction of the attacker for the primary defender, and a surround-shrink-capture strategy is proposed for the auxiliary defender. This paper is organized as follows. In Section 2, the problem is concisely described and formulated. Then, the motion strategies for the target and the defenders are presented in Sections 3 and 4, respectively. In Section 5, a numerical simulation is demonstrated to verify the effectiveness of the proposed method. Finally, Section 6 concludes this paper.
2. Problem formulation
In this section, we describe a target-attacker-defender differential game where the positions of all agents are available to all players. From the perspective of motion strategy design, it is assumed that the players can be simplified into points in this paper, although the dynamics of the players may have impact on motion control.
We consider the game in the case of one target, one attacker, and multiple defenders, denoted as
 $T$
,
 $A$
, and
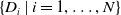 $\left \{D_{i} \mid i=1, \ldots, N\right \}$
, respectively. In order to eliminate impact on the performance caused by maneuvering capabilities, it is assumed that the speed of the attacker and defender is the same, both greater than the speed of the target, that is,
 $v_{A}=v_{D}\gt v_{T}$
. The target can only move within a certain circular area
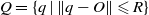 $Q=\{q \mid \|q-O\| \leqslant R\}$
, where
 $q$
is the coordinate of any point in the two-dimensional plane,
 $O$
is the center of the circular area, and
 $R$
is the radius of the circular area. The defenders and the attackers can move freely.
Define the distance between the attacker
 $A$
and the target
 $T$
at time
 $t$
as
 \begin{equation} d_{A T}(t)=\left \|A(t)-T(t)\right \| \end{equation}
Denote
 $r_{c}$
as the capture distance, such that, if
 $d_{A T}(t) \leqslant r_{c}$
, the attacker
 $A$
capture the target
 $T$
. Define the minimum distance from the attacker to all defenders at time
 $t$
as
 \begin{equation} d_{A D, \text{ min }}(t)=\underset{i}{\arg \min }\left \|D_{i}(t)-A(t)\right \| \end{equation}
If
 $d_{A D \text{,min }}(t) \leqslant r_{c}$
, it is deemed that the attacker is captured by the defender. When any of the attacker or target is captured, the game ends.
3. The motion strategy of the target
This section considers the motion strategy of the target within a constrained area, where
 $D_{T D_{-} \min }$
is the closest defender to the target. Denote
 $r_T$
as the distance between the target and the center of the circular area
 $O$
. Denote
 $\theta$
as
 $\angle{TDA} \in [0,\pi ]$
. If
 $\theta =\pi$
, the target, the defender, and the attacker are aligned in line sequentially, that is the defender is located between the target and the attacker. In this case, the attacker is not able to capture the target before being captured by the defender, and therefore it is considered as fully defense of the target. Denote
 $d_1$
,
 $d_2$
,
 $d_3$
as the distances between the attacker and the defender, the defender and the target, the target and the attacker, and denote
 $\phi _{1}$
,
 $\phi _{2}$
,
 $\phi _{3}$
as the heading angles of the attacker, the target and the defender, respectively, as shown in Figure 1.
Case 1: the target outside the annular area and closer to the defender.

Taking a constant value
 $R^{\prime }$
that satisfies
 $R^{\prime }\lt R$
, an annular region is formed by
 $Q^{\prime }=\left \{q \mid R^{\prime } \leqslant \|q-O\| \leqslant R\right \}$
, and thus,
 $Q^{\prime }\subset Q$
holds. It is assumed that if the target is located within the annular region, active defense seeking is prohibited. According to the initial distribution of the players, the problem can be classified into three different cases. Case 1:
 $T \notin Q^{\prime }$
and
 $d_2 \leqslant d_3$
; Case 2:
 $T \notin Q^{\prime }$
and
 $d_2 \gt d_3$
; Case 3:
 $T \in Q^{\prime }$
.
In Case 1, the objective of the target is to increase the angle
 $\theta$
, such that to achieve the fully defense situation. The derivative of
 $\theta$
can be formulated as
 \begin{equation} \dot{\theta }=-\frac{v_A}{d_{1}} \sin \phi _{1}+\frac{v_D}{d_{1}} \sin \phi _{3}-\frac{v_T}{d_{2}} \sin \phi _{2}+\frac{v_D}{d_{2}} \sin (\theta -\phi _{3}) \end{equation}
In order to increase
 $\theta$
,
 $\dot{\theta }$
should larger be than 0, and the larger
 $\dot{\theta }$
the faster
 $\theta$
increases. Thus, from the target perspective, the third term in Eq. (3) should be maximized, such that
 \begin{equation} \max _{\phi _{2}} \dot{\theta }=\max _{\phi _{2}}\left (-\frac{v_T}{d_{2}} \sin \phi _{2}\right ) \end{equation}
It can be seen when
 $\phi _2= -\pi /2$
,
 $\dot{\theta }$
maximized. Thus, the target should move at the speed of
 $v_T$
with the heading angle
 $-\pi /2$
in case 1.
In Case 2, the attacker is closer to the target than the defender. Since the speed of the attacker is larger than the target, pure escaping strategy for the target may not be suitable. Thus, the target has to seek for defense actively while escaping from the attacker, as shown in Figure 2. Define
 $\boldsymbol{n}_{1}$
as the vector pointing from the attacker to the target with
 $\left \| n_1 \right \| = 1/d_3$
, and
 $\boldsymbol{n}_{2}$
as the vector perpendicular to
 $n_1$
and pointing to the defender side with
 $ \|n_2\| = d_2$
. Then, the target should move with the speed
 $v_{T}$
along the direction of a resultant vector defined as
 \begin{equation} \boldsymbol{F}_{T_{-} 1}=\frac{\boldsymbol{n}_{1}+\boldsymbol{n}_{2}}{\left \|\boldsymbol{n}_{1}+\boldsymbol{n}_{2}\right \|} \end{equation}
Case 2: the target outside the annular area and closer to the attacker.

Case 3: the target inside the annular area.

In Case 3, the target is within the annular area
 $Q^{\prime }$
, as shown in Figure 3. On the one hand, the target should move inwards the restricted area in order to satisfy the territorial constrain, and on the other hand, it should move away from the attacker as far as possible to extend its own survival time. Therefore, to achieve both objectives, the target has to move along the direction of the vector
 $\boldsymbol{F}_{T_{-} 2}$
with the maximum speed
 $v_{T}$
in this case. The vector
 $\boldsymbol{F}_{T_{-} 2}$
is defined as
 \begin{equation} \boldsymbol{F}_{T_{-} 2}=\frac{\boldsymbol{n}_{1}+\boldsymbol{n}_{3}}{\left \|\boldsymbol{n}_{1}+\boldsymbol{n}_{3}\right \|} \end{equation}
where
 $\boldsymbol{n}_{3}$
is the vector pointing from the target to the center
 $O$
with
 $\left \|{{n_3}} \right \|=1/(R-r_T)$
.
4. The motion strategy of the defenders
This section considers the motion strategy design of each defender. In the game, each defender can only collect the position information of the target, attacker, and other defenders as input for the control strategy. Based on the relative positions of each agent, we first select a certain defender as the primary defender, while the other defenders are auxiliary defenders. The primary defender integrates the protection intention of the target and the capture intention of the attacker. The main concern of the auxiliary defenders is to surround the attacker and then narrow the encirclement.
4.1. Motion strategy for primary defender
We denote the defender closest to the target as the primary defender, and
 $\boldsymbol{r}_{1}, \boldsymbol{r}_{2}$
are the unit vectors directed by the defender toward the attacker and target, respectively. The
 $d_{1}, d_{2}$
are the distances from the primary defender
 $D_{T D_{-} \min }$
to the attacker and the target, respectively. Define
 $\beta$
as the angle formed by the attacker as the center and the line connecting the attacker to the primary defender and the target as the edges, as shown in Figure 4.
Schematic diagram of primary defender’s strategy.

The attacker has the possibility to go toward the target or away from the defender because the attacker’s motion strategy is isolated to the target and the defenders. We predict the attacker’s attack intention based on changes in its position to design the motion strategy of the primary defender. At the initial moment, the defender does not have the position information in the previous moment, so it is stipulated that the primary defender adopts a pure pursuit strategy at the initial moment, which is to move toward the attacker, with the speed being the maximum speed
 $v_{D}$
. For other moments, the following will analyze and design the motion strategy of the primary defender based on the relative positions of each agent.
If
 $\beta =\pi$
, the attacker is located on the line between the primary defender and the target, and the unit vector
 $\boldsymbol{r}_{1}, \boldsymbol{r}_{2}$
are the same vector. Due to the same maximum speed between the defender and the attacker, it is difficult for the defender to capture the attacker individually. To cooperate with the target or other defenders, the primary defender should move in the direction of the unit vector
 $\boldsymbol{r}_{1}$
to minimize the distance from the attacker and approach the target as much as possible. It is stipulated that the speed of the primary defender at this time is
 $v_{D}$
.
If
 $0\lt \beta \lt \pi$
, the primary defender should move between the attacker and the target to prevent the attacker from approaching the target. When the primary defender moves to the line between the attacker and the target, the attacker must bypass the primary defender to capture the target. As the distance between the primary defender and the target is closer than the distance between the attacker and the target, and the maximum speed of both the defender and the attacker is the same, the primary defender can effectively prevent the target from being captured.
Denote
 $T^{-},\, A^{-},\, D_{T D_{-} \min }^{-}$
as the target
 $T$
, attacker
 $A$
, and defender
 $D_{T D_{-} \min }$
at the previous moment, as shown in Figure 5. In the figure, the angle
 $\beta ^{-}$
is formed by the attacker
 $A^{-}$
as the center, the lines connecting the attacker
 $A^{-}$
to the defender
 $D_{T D_{-} \min }^{-}$
and the target
 $T^{-}$
as the edges, the angle
 $\vartheta$
is formed by the attacker
 $A^{-}$
as the center, the lines connecting the attacker
 $A^{-}$
to the defender
 $D_{T D_{-} \text{min }}^{-}$
and the current attacker
 $A$
as the edges, and
 $\boldsymbol{n}_{A, 1}, \boldsymbol{n}_{A, 2}$
are the components of the vectors formed by the lines connecting the attacker
 $A^{-}$
to the attacker
 $A$
in different directions, where
 $\boldsymbol{n}_{A, 1}$
along the direction of the defender
 $D_{T D_{-} \min }^{-}$
pointing toward the attacker
 $A^{-}, \boldsymbol{n}_{A, 2}$
along the direction of the attacker
 $A^{-}$
pointing toward the target
 $T^{-}$
.
Intention prediction of the attacker.

Furthermore, the attack intention of the attacker
 $A^{-}$
can be analyzed through the included angle
 $\vartheta$
, which can be used to generate the primary defender’s motion strategy at the current moment. The components
 $\boldsymbol{n}_{A, 1}, \boldsymbol{n}_{A, 2}$
represent the attacker’s intention to stay away from the primary defender and its intention to capture the target, respectively. Thus, we define the attacker’s attack intention
 \begin{equation} f(\vartheta )=\left \{\begin{array}{c@{\quad}l} 1, & 0\lt \vartheta \leq \beta ^{-} \\ \frac{\left \|\boldsymbol{n}_{A, 2}\right \|}{\left \|\boldsymbol{n}_{A, 1}\right \|+\left \|\boldsymbol{n}_{A, 2}\right \|}, & \beta ^{-}\lt \vartheta \leq \pi \end{array}\right . \end{equation}
We assume that the attacker’s attack intention is 1 if
 $0\lt \vartheta \leq \beta ^{-}$
. And if
 $\beta ^{-}\lt \vartheta \leq \pi$
, from a geometric perspective, it can be inferred that if a constant value
 $h=\left \|\boldsymbol{n}_{A, 1}\right \| \sin (\pi -\vartheta )$
, then
 $h=\left \|\boldsymbol{n}_{A, 2}\right \| \sin \left (\vartheta -\beta ^{-}\right )$
, thus
 \begin{equation} f(\vartheta )=\frac{\sin \vartheta }{2 \sin \frac{2 \vartheta -\beta ^{-}}{2} \cos \frac{\beta ^{-}}{2}}, \quad \beta ^{-}\lt \vartheta \leq \pi \end{equation}
where if
 $\vartheta =\pi, \ f(\vartheta )=0$
, the attacker moves in the opposite direction of the line connecting with the defender
 $D_{T D_{-} \text{min }}^{-}$
, without any intention of attacking the target. And if
 $\lim \vartheta =\beta ^{-}$
, it is known that the function
 $f(\vartheta )$
is continuous at
 $\vartheta =\beta ^{-}$
, and the attacker moves along the direction of the line connecting the target
 $T^{-}$
, without considering the influence of the primary defender.
Meanwhile, it is necessary to consider the two cases where the denominator in the Eq. (8) is zero, which are
 $\beta ^{-}=2 \vartheta, \ \beta ^{-}=\pi$
, respectively. If
 $\beta ^{-}=2 \vartheta$
, then
 $\beta ^{-}\gt \vartheta$
, it contradicts the conditions
 $\beta ^{-}\lt \vartheta \leq \pi$
, so we do not consider this case. It can be seen that
 $\beta ^{-}\lt \pi$
, in contradiction to the case
 $\beta ^{-}=\pi$
, this case is not considered. From this, the attacker’s attack intention
 $f(\vartheta )$
at the previous moment can be determined based on the included angle
 $\vartheta$
.
Therefore, if
 $0\lt \beta \lt \pi$
, it is stipulated that the primary defender
 $D_{T D_{-} \min }$
moves at
 $v_{D}$
, and its motion direction is
 \begin{equation} \boldsymbol{F}_{D}=\boldsymbol{r}_{1}+\frac{d_{2}}{d_{1}} f(\vartheta ) \boldsymbol{r}_{2} \end{equation}
where if the attack intention
 $f(\vartheta )=0,\ \boldsymbol{F}_{D}=\boldsymbol{r}_{1}$
, the primary defender moves in the direction of the vector
 $\boldsymbol{r}_{1}$
to capture the attacker; if the attack intention
 $f(\vartheta )=1, \boldsymbol{F}_{D}=\boldsymbol{r}_{1}+\frac{d_{2}}{d_{1}} \boldsymbol{r}_{2}$
, the primary defender moves between the attacker and the target, taking into account the impact of the distance
 $d_{1}, d_{2}$
.
According to the Eq. (9), if the distance between the primary defender and the target is closer, the distance ratio
 $d_{2} / d_{1}$
is small, so the coefficient of the term
 $\boldsymbol{r}_{2}$
is small. The primary defender’s motion direction is mainly shifted toward the attacker’s side, thus avoiding collisions with the target. If the distance between the defender and the target is far, the distance ratio
 $d_{2} / d_{1}$
is large, so the coefficient of the term
 $\boldsymbol{r}_{2}$
is large. The primary defender’s motion direction mainly shifts toward the target side, protecting the target from being captured by constantly approaching the target. As can be seen from the above, the setting of the coefficient term
 $d_{2} / d_{1}$
can enable the primary defender to adjust their motion direction in real-time based on the relative positions of each agent, to protect the target while considering capturing the attacker.
4.2. Motion strategy for auxiliary defenders
All defenders except the primary defender are auxiliary defenders. If the attacker is located inside a convex polygon formed by the defenders, the attacker is considered as surrounded. If there is only one auxiliary defender, this defender and the primary defender cannot form an encirclement. Thus, it is stipulated that this auxiliary defender is a pursuing defender, intending to capture the attacker. If there are multiple auxiliary defenders, the auxiliary defender closest to the attacker is considered as the surrounding defender, and the other auxiliary defenders are considered as the pursuing defenders.
Define
 $D_{i}(t)=\left (x_{i}, y_{i}\right )$
is the position of the pursuing defender
 $D_{i}$
at the current time,
 $A(t)=\left (x_{A}, y_{A}\right )$
is the position of the attacker at the current time, and
 $d_{A, i}$
is the distance from the defender
 $D_{i}$
to the attacker. The defender
 $D_{i}$
’s heading angle
 $\varphi _{i}$
is the angle between its motion direction and the horizontal direction, as shown in Figure 6. For the pursuing defenders, they intend to capture the attacker, so they should minimize the distance from themselves to the attacker as much as possible. Thus, a cost function for the pursuing defenders can be constructed as
 \begin{equation} J_{i}=d_{A, i}^{2}=\left (x_{i}-x_{A}\right )^{2}+\left (y_{i}-y_{A}\right )^{2} \end{equation}
The motion equation of the pursuing defender
 $D_{i}$
is
 \begin{equation} \left \{\begin{array}{l} \dot{x}_{i}=\left \|\dot{D}_{i}(t)\right \| \cos \varphi _{i} \\ \dot{y}_{i}=\left \|\dot{D}_{i}(t)\right \| \sin \varphi _{i} \end{array}\right . \end{equation}
Thus, the derivative of the cost function
 \begin{equation} \begin{aligned} \dot{J}_{i} & =2 \dot{x}_{i} x_{i}+2 \dot{x}_{A} x_{A}-2 \dot{x}_{i} x_{A}-2 x_{i} \dot{x}_{A}+2 \dot{y}_{i} y_{i}+2 \dot{y}_{A} y_{A}-2 \dot{y}_{i} y_{A}-2 y_{i} \dot{y}_{A} \\ & =2\left \|\dot{D}_{i}(t)\right \| \cos \varphi _{i}\left (x_{i}-x_{A}\right )+2 \dot{x}_{A} x_{A}-2 x_{i} \dot{x}_{A}+2\left \|\dot{D}_{i}(t)\right \| \sin \varphi _{i}\left (y_{i}-y_{A}\right )+2 \dot{y}_{A} y_{A}-2 y_{i} \dot{y}_{A} \\ & =2\left \|\dot{D}_{i}(t)\right \|\left [\left (x_{i}-x_{A}\right ) \cos \varphi _{i}+\left (y_{i}-y_{A}\right ) \sin \varphi _{i}\right ]+2 \dot{x}_{A} x_{A}-2 x_{i} \dot{x}_{A}+2 \dot{y}_{A} y_{A}-2 y_{i} \dot{y}_{A} \end{aligned} \end{equation}
By solving the Eq. (12), it can be seen that if the pursuing defender wants to minimize the cost function
 $J_{i}$
, this defender’s speed
 $\left \|\dot{D}_{i}(t)\right \|=v_{D}$
and its optimal heading angle
 \begin{equation} \cos \varphi _{i}^{*}=\frac{x_{A}-x_{i}}{d_{A, i}}, \quad \sin \varphi _{i}^{*}=\frac{y_{A}-y_{i}}{d_{A, i}} \end{equation}
It can be seen that the optimal motion strategy for the pursuing defender is the pure pursuit strategy in the case where only the position information of each agent can be obtained.
Motion strategy for pursuing defender.

In Figure 6,
 $\varphi _{A}$
is the attacker’s heading angle, and the pursuing defender
 $D_{i}$
adopts the pure pursuit strategy. Due to the influence of the target and other defenders, the attacker cannot always move in the opposite direction of the line connecting the pursuing defender, thus the derivative of the distance between the attacker and the defender
 $D_{i}$
 \begin{equation} \dot{d}_{A, i}=\|\dot{A}(t)\| \cos \varphi _{A}-\left \|\dot{D}_{i}(t)\right \|=\|\dot{A}(t)\| \cos \varphi _{A}-v_{D} \leq 0 \end{equation}
We know that the distance between the attacker and the defender is non-increasing during the game, and the case
 $\dot{d}_{A, i}=0$
is not constant. Therefore, even in the case of only one auxiliary defender, it can still ensure the completion of capturing the attacker in a limited time. If there are multiple auxiliary defenders, the motion of each defender will objectively limit the attacker’s range of activity, further reducing the time required to complete the capture.
For the surrounding defender
 $D_{\mathrm{s}}$
, as the closest auxiliary defender to the attacker, if it adopts the pure pursuit strategy, the attacker can move in the opposite direction of the line connecting the surrounding defender. Although the attacker can be captured in a limited time, the capture time is relatively long. Therefore, this paper sets up the surrounding defender first completes the encirclement of the attacker to limit its activity area and then shrinks the encirclement range to reduce the time required to capture.
Define
 $B_{i}$
as the edge formed by connecting the surrounding defender with other defenders
 $D_{i}$
, and the closest to the attacker among them is
 $B_{\min }$
. As shown in Figure 7, the attacker is located outside the convex polygon formed by the defenders. In order to surround the attacker, the defenders have to trap the attacker within the convex polygon formed by the defenders, that is, to move the edge
 $B_{\min }$
toward the attacker as soon as possible. As the surrounding defender
 $D_{\mathrm{s}}$
moves one step, it could be anywhere on the dash line circle, denoted by
 $D_{\mathrm{s}}^{+}$
. From the perspective of geometry, only if the line connecting the defender
 $D_{\mathrm{s}_{\_} \mathrm{m}}$
and
 $D_{\mathrm{s}}^{+}$
is tangent to the dash line circle, the edge
 $B_{\min }$
approaches the attacker the most. Denote the radius of the dash line circle as
 $d_{\mathrm{q}}$
, and the length of the edge
 $B_{\min }$
as
 $d_{B}$
, then the optimal motion direction of the surrounding defender is obtained as
 \begin{equation} \varphi _{\mathrm{s}}^{*}=\arccos \frac{d_{\mathrm{q}}}{d_{B}} \end{equation}
When the attacker is inside a convex polygon formed by the lines connecting the positions of each defender, each auxiliary defender should continuously shrink the surrounding area to limit the attacker’s range of activity to capture the attacker. As shown in Figure 8, the attacker is surrounded by multiple defenders. We number each defender and designate the primary defender as
 $D^{1}$
, that is,
 $D_{T D_{-} \min }=D^{1}$
. The number of each defender increases sequentially in a counterclockwise manner with the attacker as the center. Then the auxiliary defenders could be denoted as
 $\left \{D^{i} \mid i=2, \ldots N\right \}$
.
Motion strategy for surrounding defender.

The attacker surrounded by multiple defenders.

In Figure 8,
 $\theta _{i, i-}$
is the angle formed by the attacker as the center and the line connecting the attacker and the defender
 $D^{i}, D^{i-}$
as the edge,
 $\theta _{i, i+}$
is the angle formed by the attacker as the center and the line connecting the attacker and the defender
 $D^{i}, D^{i+}$
as the edge, where
 \begin{equation} i-=\left \{\begin{array}{cl} i-1, & \text{ if } \mathrm{i}\gt 1 \\ N, & \text{ if } i=1 \end{array}, \quad i+=\left \{\begin{array}{cl} i+1, & \text{ if } i\lt N \\ 1, & \text{ if } i=N \end{array}\right .\right . \end{equation}
And
 $\boldsymbol{n}_{D, i}$
is the unit vector pointed by the defender
 $D^{i}$
toward the attacker,
 $\boldsymbol{n}_{D+, i}$
is the unit vector perpendicular to the vector
 $\boldsymbol{n}_{D, i}$
and pointing toward the direction of reducing the included angle
 $\theta _{i, i+}$
.
This paper designs the motion strategy of the auxiliary defender
 $D^{i}$
during the shrinking stage
 \begin{equation} \boldsymbol{u}_{i}=v_{D} \frac{\boldsymbol{n}_{D, i}+\lambda \sin \left (\frac{\theta _{i, i+}-\theta _{i, i_{-}}}{2}\right ) \boldsymbol{n}_{D+, i}}{\left \|\boldsymbol{n}_{D, i}+\lambda \sin \left (\frac{\theta _{i, i+}-\theta _{i, i-}}{2}\right ) \boldsymbol{n}_{D+, i}\right \|} \end{equation}
where
 $\lambda$
is the conversion coefficient. Under this strategy, on the one hand, the defender
 $D^{i}$
can continuously approach the attacker, and on the other hand, it can adjust its motion direction based on the gap between adjacent defenders on both sides, thereby maintaining the stability of the surrounding formation, and limit the attacker’s range of activity.
Through the above content, the motion strategies of each auxiliary defender in the game can be obtained. The pseudo-code of the auxiliary defenders’ motion strategy is shown in Algorithm1.
Generation of the auxiliary defenders’ motion strategy

5. Numerical simulation
This section first designs the attacker’s motion strategy and sets various parameters in the simulation. Then, in the case of two defenders, a comparative experiment is conducted to verify the effectiveness of the primary defender’s motion strategy. And by simulating the case where there are three defenders, we analyze the impact of the surround-shrink-capture strategy of auxiliary defenders on the game.
5.1. Simulation settings
The objective of the attacker is capturing the target and at the same time escaping from the defenders, and the only available information about the game is the position information of all players. Therefore, it is suitable for the attacker to employ a position-based motion strategy. Since the artificial potential field method is mainly based on the position (distance) information, it is adopted to determine the motion strategy of the attacker in the numerical simulation. That is, the attacker will be subjected to attractive force from the target and repulsive force from various defenders. Define the size of the attacker’s attractive force from the target
 \begin{equation} \left \|\boldsymbol{F}_{\mathrm{att}}(A)\right \|= \begin{cases}\xi d_{\mathrm{t}}, & \text{ if } d_{\mathrm{a}, \mathrm{t}} \leq d_{\mathrm{t}} \\ \xi d_{\mathrm{a}, \mathrm{t}}, & \text{ if } d_{\mathrm{a}, \mathrm{t}}\gt d_{\mathrm{t}}\end{cases} \end{equation}
where
 $\xi$
is the attractive gain coefficient,
 $d_{\mathrm{t}}$
is the target’s maintain distance,
 $d_{\mathrm{a}, \mathrm{t}}$
is the distance between the attacker and the target, and the direction of this attractive force is directed by the attacker toward the target. It can be seen that if the distance
 $d_{\mathrm{a}, \mathrm{t}}$
is greater than or equal to the maintain distance
 $d_{\mathrm{t}}$
, the larger the distance
 $d_{\mathrm{a}, \mathrm{t}}$
, the greater the attractive force on the attacker; if the distance
 $d_{\mathrm{a}, \mathrm{t}}$
is less than the maintain distance
 $d_{\mathrm{t}}$
, the attractive force received by the attacker remains unchanged, thereby avoiding the target unreachable problem caused by too small attractive force.
Define the size of repulsion the attacker receives from the defender
 $D_{i}$
 \begin{equation} \left \|\boldsymbol{F}_{\mathrm{req}}^{i}(A)\right \|= \begin{cases}\eta \left [\frac{1}{d_{A, i}}-\frac{1}{d_{c, i}}\right ] \frac{1}{d_{A, i}}, & \text{ if } d_{A, i} \leq d_{c, i} \\ 0, & \text{ if } d_{A, i}\gt d_{c, i}\end{cases} \end{equation}
where
 $\eta$
is the repulsion gain coefficient,
 $d_{c, i}$
is the defender
 $D_{i}$
’s influence distance,
 $d_{A, i}$
is the distance between the attacker and the defender
 $D_{i}$
, and the direction of this repulsion is directed by the defender
 $D_{i}$
toward the attacker. It can be seen that if the distance
 $d_{A, i}$
is less than or equal to the influence distance
 $d_{c, i}$
, the smaller the distance
 $d_{A, i}$
, the greater this repulsion force; if the distance
 $d_{A, i}$
is greater than the influence distance
 $d_{c, i}$
, the attacker receives zero repulsion from the defender
 $D_{i}$
.
Simulation results with two equivalent defenders.

Simulation results with two classified defenders.

Simulation results of pure pursuit strategy.

Simulation results of surround-shrink-capture strategy.

Furthermore, the resultant force received by the attacker is the superposition of the attractive force from the target and the repulsive force from various defenders:
 \begin{equation} \boldsymbol{F}(A)=\boldsymbol{F}_{\mathrm{att}}(A)+\sum _{i=1}^{N} \boldsymbol{F}_{\mathrm{req}}^{i}(A) \end{equation}
We specify the direction of the resultant force as the direction of the attacker’s motion, and the speed is
 $v_{A}$
. As a result, the attacker can approach the target as close as possible, and adjust its motion direction in real-time to avoid being caught by the defender.
Meanwhile, we set the maximum speed
 $v_{T}=10 \mathrm{\,m} / \mathrm{s},\ v_{A}=20 \mathrm{\,m} / \mathrm{s},\ v_{D}=20 \mathrm{\,m} / \mathrm{s}$
, capture distance
 $r_{c}=100 \mathrm{\,m}$
, and the target can only move within a circle with a radius
 $R=1 \mathrm{\,km}$
, and the center coordinate of this circle is
 $(0,0)$
. In the design of the target’s motion strategy, we take the constant value
 $R^{\prime }=0.8 \mathrm{\,km}$
. In the design of the attacker’s motion strategy, we set
 $d_{\mathrm{q}}=20 \mathrm{\,m}$
, the conversion coefficient
 $\lambda =5$
. In the design of the defenders’ motion strategy, the attractive gain coefficient
 $\xi =0.5$
, repulsive gain coefficient
 $\eta =0.4$
, the maintain distance
 $d_{\mathrm{t}}=1.5 \mathrm{\,km}$
, and the influence distance
 $d_{c, i}=0.2 \mathrm{\,km},{} i=1 \ldots N$
.
5.2. Simulation results and analysis
This section simulates and analyzes the case where there are two or three defenders. The simulation with two defenders is shown in Figures 9 and 10, and the simulation with three defenders is shown in Figures 11 and 12. In the figure, the labels
 $\textrm{A}$
,
 $\textrm{D1}$
,
 $\textrm{D2}$
, and
 $\textrm{D3}$
represent the initial positions of the attacker and defender
 $D_1$
,
 $D_2$
, and
 $D_3$
, respectively. The curves starting from the corresponding labels represent the motion trajectories of each agent. The label T represents the real-time position of the target at various times, and the light-yellow circular area represents the restricted area where the target is located. The motion trajectory of the defender is a light green dashed line, while the motion trajectory of the attacker is an orange solid line. The hollow end of each trajectory represents the current position of each agent.
For the case where there are two defenders, the initial position of the target is set as (0,0), the initial position of the attacker is set as (0.7, 0.8), and the initial positions of the two defenders are set as (1.0, 1.5) and (−1.5, 0.7), respectively. In Figure 9, the target adopts the motion strategy proposed in this paper while the defenders all adopt a pure pursuit strategy, moving toward the attacker at the maximum speed. From the game process, it can be seen that the target cooperates with the defenders, constantly adjusting its position to avoid being captured by the attacker. The attacker receives repulsion from various defenders and attraction from the target, and then tries to approach the target as close as possible while avoiding the defenders. Due to the relatively close distance between the attacker and the target in the initial stage, the two defenders are unable to protect the target in a timely and effective manner. When
 $t = 74{\textrm{s}}$
, the distance from the attacker to the target was less than the capture distance
 $r_c$
, and then the attacker successfully captured the target
 $T$
, the game ended as shown in Figure 9(e).
In Figure 10, the target and each defender adopt the motion strategy proposed in this paper, while keeping the initial positions of each agent unchanged. In the game, the defender
 $D_2$
was the primary defender, following the proposed strategy in this paper to prevent the attacker from approaching the target. The defender
 $D_1$
was an auxiliary defender and adopted a pure pursuit strategy, moving toward the attacker at the maximum speed. According to the game process, when
 $t = 68{\textrm{s}}$
, the attacker was forced to move away from the target under the approach of the defender
 $D_2$
. When
 $t = 84{\textrm{s}}$
, the distance between the attacker and the defender
 $D_2$
was less than the capture distance
 $r_c$
, and then the defender completed the capture of the attacker, the game ended, as shown in Figure 10(e). As shown in Figure 10(f), the distance from the attacker to the target first decreases and then continuously increases, while the distance between the attacker and the nearest defender decreases continuously, eventually falling below the capture distance
 $r_c$
. It can be seen that the motion strategy proposed for the primary defender in this paper can more effectively protect the target
 $T$
by predicting the attacker’s attack intention.
For the case where there are three defenders, the initial position of the target is set as (0,0), the initial position of the attacker is set as (1.5, 1.8), and the initial positions of the three defenders are set as (1.0, 1.5), (−0.8, 1.2), and (1.8, −0.5), respectively. In Figure 11, both the target and the primary defender adopt the motion strategy proposed in this paper, while the auxiliary defenders adopt the pure pursuit strategy. From the game process, it can be seen that the defender
 $D_2$
was the primary defender, effectively preventing the attacker from approaching the target. Auxiliary defenders
 $D_1$
and
 $D_3$
closely follow the attacker to reduce the distance between themselves and the attacker. When
 $t = 307{\textrm{s}}$
, the distance between the attacker and the defender
 $D_2$
was less than the capture distance
 $r_c$
, and then the defender completed the capture of the attacker, the game ended, as shown in Figure 11(e). Although the defender ultimately succeeded in capturing the attacker, the capture time was relatively long and failed to leverage the advantages of multiple agents.
In Figure 12, both the target and the defenders adopt the motion strategy proposed in this paper, where the initial positions of each agent are the same as in Figure 11. When
 $0{\textrm{s}} \le t \le 40{\textrm{s}}$
, the attacker was located outside the convex polygon formed by three defenders. The defender
 $D_2$
was the primary defender, and the defenders
 $D_1$
and
 $D_3$
were the auxiliary defenders. The auxiliary defender
 $D_1$
was the closest to the attacker and implemented a surround strategy according to Algorithm1. The auxiliary defender
 $D_3$
adopted a pure pursuit strategy and kept approaching the attacker. When
 $40\textrm{s} \lt t \lt 116{\textrm{s}}$
, the attacker was located inside the convex polygon formed by three defenders, thus the auxiliary defenders
 $D_1$
and
 $D_3$
adopted a shrink strategy according to Algorithm1, constantly approaching the attacker while maintaining the stability of the encirclement. When
 $t = 116{\textrm{s}}$
, the distance between the attacker and the defender
 $D_2$
was less than the capture distance
 $r_c$
, and then the defender completed the capture of the attacker, the game ended, as shown in Figure12(e). It can be seen that the surround-shrink-capture strategy designed for auxiliary defenders can greatly reduce the time required to capture attackers.
6. Conclusion
This paper mainly studies the target-attacker-defender game where the target is in a restricted area, and each agent can collect and utilize the position information only. We analyze and design the motion strategies for the target and each defender. The target and each defender cooperate with each other to capture the attacker as much as possible while protecting the target from being captured. In the design of motion strategies for the defenders, we divide defenders into primary defenders and auxiliary defenders: the primary defender is mainly responsible for protecting the target from capture and the auxiliary defenders adopt the surround-shrink-capture strategy to reduce the time required to capture the attacker. Through simulation and comparative analysis, the impact of the number of defenders and the surround-shrink-capture strategy of auxiliary defenders on the game results is obtained. In the future, we plan to investigate the TAD game with more practical motion models of the agents and analyze the case where multiple attackers exist.
Author contributions
G. Dong and Q. Mi conceived and designed the study. Y. Xing conducted data gathering and performed statistical analyses. Y. Xing and G. Dong wrote the article. G. Dong addressed the reviewers’ comments and revised the paper.
Financial support
This work is supported in part by the National Natural Science Foundation of China under Grant No. 62273278.
Competing interests
The authors declare no conflicts of interest exist.
Ethical approval
Not applicable.



